

Page 1
www.fairchildsemi.com
FAN5240
Multi-Phase PWM Controller for AMD Mobile
Athlon
TM
and Duron
TM
Features
• CPU Core power: 0.925V to 2.0V output range
• ±1% reference precision over temperature
• Dynamic voltage setting with 5-bit DAC
• 5V to 24V input voltage range
• 2 phase interleaved switching
• Active droop to reduce output capacitor size
• Differential remote voltage sense
• High efficiency:
>90% efficiency over wide load range
>80% efficiency at light load
• Excellent dynamic response with Voltage Feed-Forward
and Average Current Mode control
• Dynamic duty cycle clamp minimizes inductor current
build up
• Lossless current sensing on low-side MOSFET or
Precision current sensing using sense resistor
• Fault protections: Over-voltage, Over-current, and
Thermal Shut-down
• Controls: Enable, Forced PWM, Power Good, Power
Good Delay
• QSOP28, TSSOP28
Applications
• AMD Mobile Athlon CPU V
• AMD Mobile Duron CPU V
CORE
CORE
Regulator
Regulator
General Description
The FAN5240 is a single output 2-Phase synchronous buck
controller to power AMD’s mobile CPU core. The FAN5240
includes a 5-bit digital-to-analog converter (DAC) that
adjusts the core PWM output voltage from 0.925VDC to
2.0VDC, which may be changed during operation. Special
measures are taken to allow the output to transition with
controlled slew rate to comply with AMD’s Power Now
technology. The FAN5240 includes a precision reference,
and a proprietary architecture with integrated compensation
providing excellent static and dynamic core voltage regulation. The regulator includes special circuitry which balances
the 2 phase currents for maximum efficiency.
At light loads, when the filter inductor current becomes
discontinuous, the controller operates in a hysteretic mode,
dramatically improving system efficiency. The hysteretic
mode of operation can be inhibited by the FPWM control
pin.
The FAN5240 monitors the output voltage and issues a
PGOOD (Power-Good) when soft start is completed and the
output is in regulation. A pin is provided to add delay to
PGOOD with an external capacitor.
A built-in over-voltage protection (OVP) forces the lower
MOSFET on to prevent the output from exceeding a set
voltage. The PWM controller's overcurrent circuitry monitors the converter load by sensing the voltage drop across the
lower MOSFET. The overcurrent threshold is set by an external resistor. If precision overcurrent protection is required,
an optional external current-sense resistor may be used.
REV. 1.1.7 8/29/02
Page 2
FAN5240 PRODUCT SPECIFICATION
Typical Application
VIN (BATTERY)
= 5 to 24
+5
C3
C4
+5
R1
PGOOD
C5
FPWM
C11
0
C1
DELAY
R4
AGND
V
VCC
VID0
VID
VID
VID
VID
ILIM
EN
SS
VI
N
21
28
Phase 1
19
14
12
11
1
10
2
9
3
8
4
7
20
16
13
15
Phase 2
25
24
23
27
26
22
18
17
3
C9
4
5
1
2
6
BOOT1
Q1
HDRV
1
1
SW
Q2
LDRV
1
1
PGND
ISNS1
VCORE +
VCORE D
2
BOOT
2
HDRV
SW
2
Q5
2
LDRV
PGND2
ISNS2
R6
VIN
Q4
C1
C7
C8
Q3
C12
C13C14C16
D1
C6
Q6
C2
D2
+5
R2
C15
+5
L2L1
R3
V
CORE
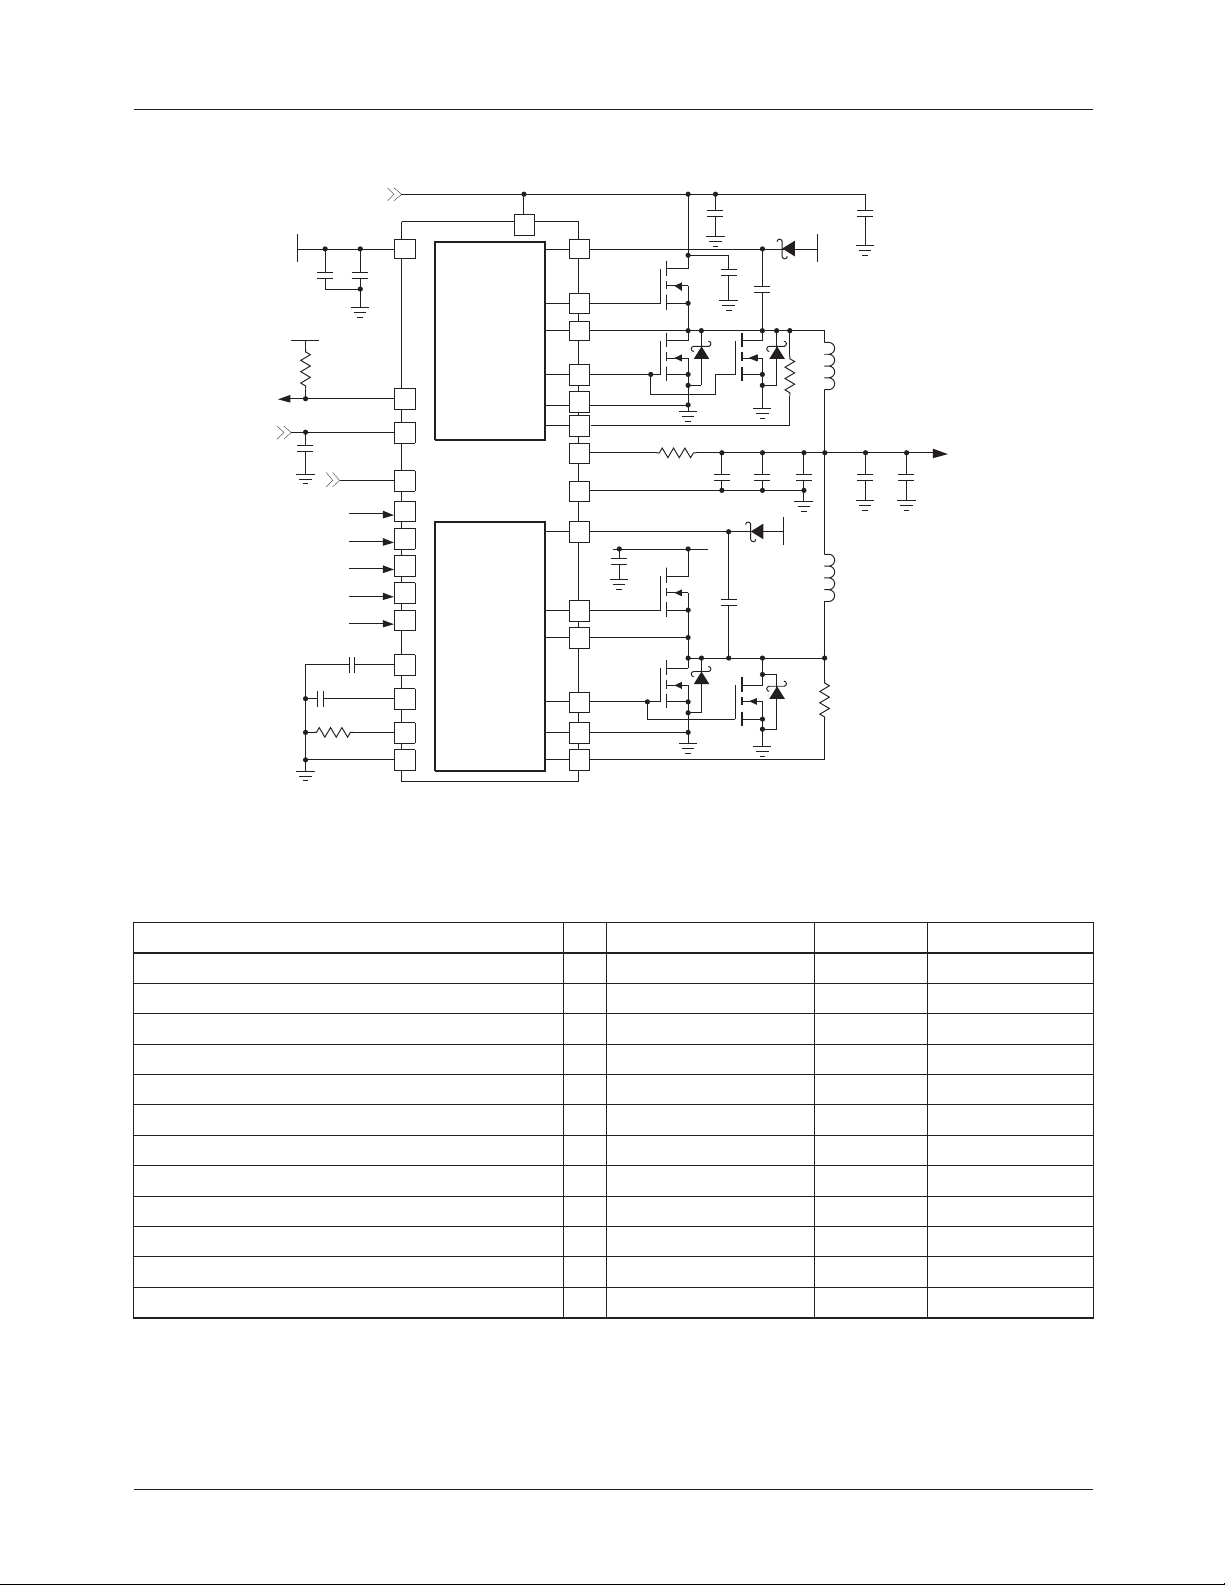
Figure 1. AMD Mobile Athlon/Duron CPU Core Supply
Table 1. BOM for Figure 1
Description Qty Ref. Vendor Part Number
Capacitor 22µF, Ceramic X7R 25V 2 C1, C2 TDK
Capacitor 1µF, Ceramic 3 C3,C7,C9 Any
Capacitor 0.1µF, Ceramic 6 C4–C6, C8, C11, C12 Any
Capacitor 0.22µF, Ceramic 1 C10 Any
Capacitor 270µF, 2V, ESR 15m Ω
4 C13–C16 Panasonic EEFUE0D271R
10K Ω , 5% Resistor 2 R1 Any
1K Ω , 1% Resistor 1 R2, R3, R6 Any
56.2K Ω , 1% Resistor 2 R4 Any
Schottky Diode 40V 2 D1, D2 Fairchild MBR0540
Inductor 1.6µH, 20A, 2.4m Ω
N-Channel SO-8 MOSFET, 11m Ω
N-Channel SO-8 SyncFET™ MOSFET, 6m Ω
1 L1, L2 Panasonic ETQP6F0R8LFA
1 Q1, Q4 Fairchild FDS6694
1 Q2, Q3, Q5, Q6 Fairchild FDS6676S
2
REV. 1.1.7 8/29/02
Page 3
PRODUCT SPECIFICATION FAN5240
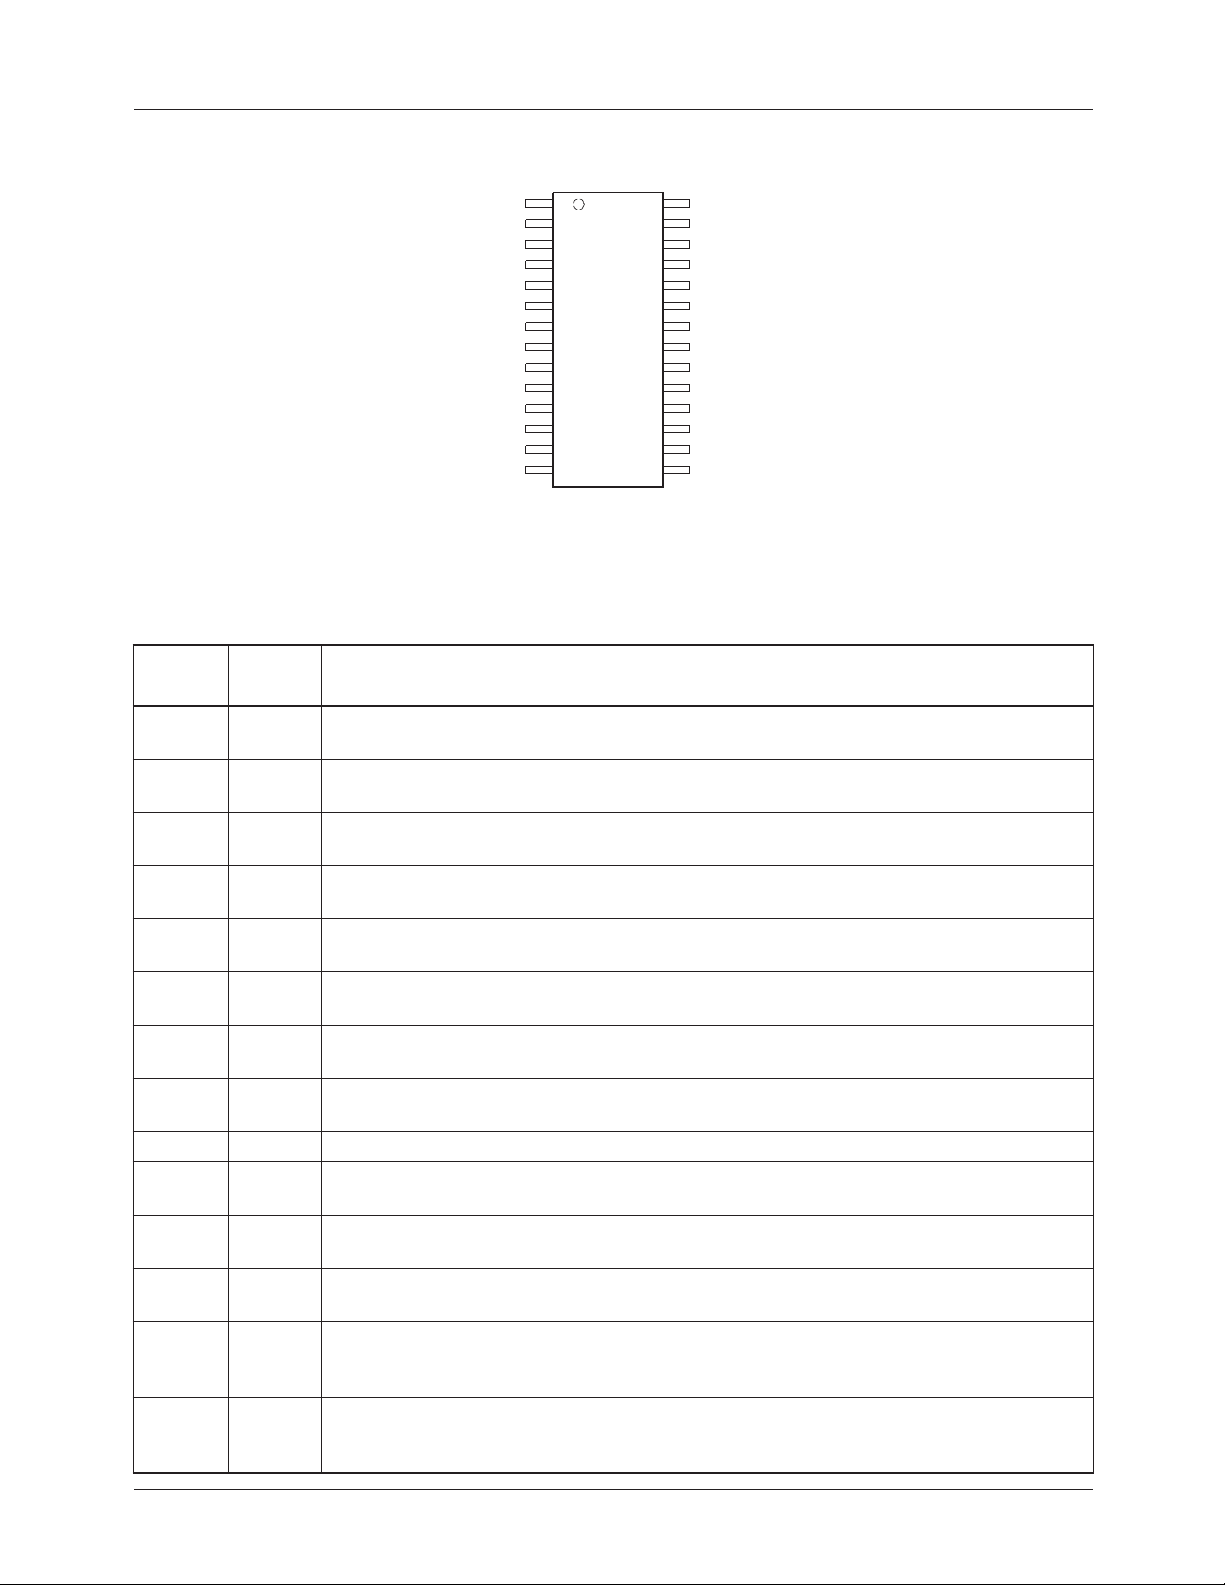
Pin Configuration
LDRV2
PGND2
BOOT2
HDRV2
SW2
ISNS2
VID4
VID3
VID2
VID1
VID0
FPWM
ILIM
1
2
3
4
5
6
7
FAN5240
8
9
10
11
12
13
EN
14
QSOP-28 or TSSOP-28
VCC
28
LDRV1
27
PGND1
26
BOOT1
25
HDRV1
24
SW1
23
ISNS1
22
VIN
21
SS
20
PGOOD
19
VCORE+
18
VCORED
17
DELAY
16
AGND
15
θJA = 90°C/W
Pin Definitions
Pin
Number
1
27
2
26
3
25
4
24
5
23
6
22
7 - 11 VID4 -
12 FPWM Forced PWM mode. When logic high, inhibits the chip from entering hysteretic operating
13 ILIM Current Limit. A resistor from this pin to GND sets the current limit.
14 EN
15 AGND Analog Ground. This is the signal ground reference for the IC. All voltage levels are
16 DELAY Power Good / Over-Current Delay. A capacitor to GND on this pin delays the PGOOD
18
17
19 PGOOD Power Good Flag. An open-drain output that will pull LOW when the core output below
Pin
Name
LDRV2
LDRV1
PGND2
PGND1
BOOT2
BOOT1
HDRV2
HDRV1
SW2
SW1
ISNS2
ISNS1
VID0
VCORE+
VCORE–
Pin Function Description
Low-Side Drive. The low-side (lower) MOSFET driver output.
Power Ground. The return for the low-side MOSFET driver.
BOOT. The positive supply for the upper MOSFET driver. Connect as shown in Figure 1.
High-Side Drive. The high-side (upper) MOSFET driver output.
Switching node. The return for the high-side MOSFET driver.
Current Sense input. Monitors the voltage drop across the lower MOSFET or external
sense resistor for current feedback.
Voltage Identification Code. Input to VID DAC. Sets the output voltage according to the
codes set as defined in Table 2. These inputs have 1 µ A internal pull-up.
mode. If tied low, hysteretic mode will be allowed.
ENABLE. This pin enables IC operation when either left open, or pulled up to VCC.
Toggling EN will also reset the chip after a latched fault condition.
measured with respect to this pin.
from going high as well delaying the over-current shutdown.
VCORE Output Sense. Differential sensing of the output voltage. Used for regulation as
well as PGOOD, under-voltage and over-voltage protection and monitoring. A resistor in
series with this VCORE+ sets the output voltage droop.
825mV. PGOOD delays its low to high transition for a time determined by CDELAY when
VCORE rises above 875mV.
REV. 1.1.7 8/29/02
3
Page 4
FAN5240 PRODUCT SPECIFICATION
Pin Definitions
Pin
Number
20 SS
21 VIN
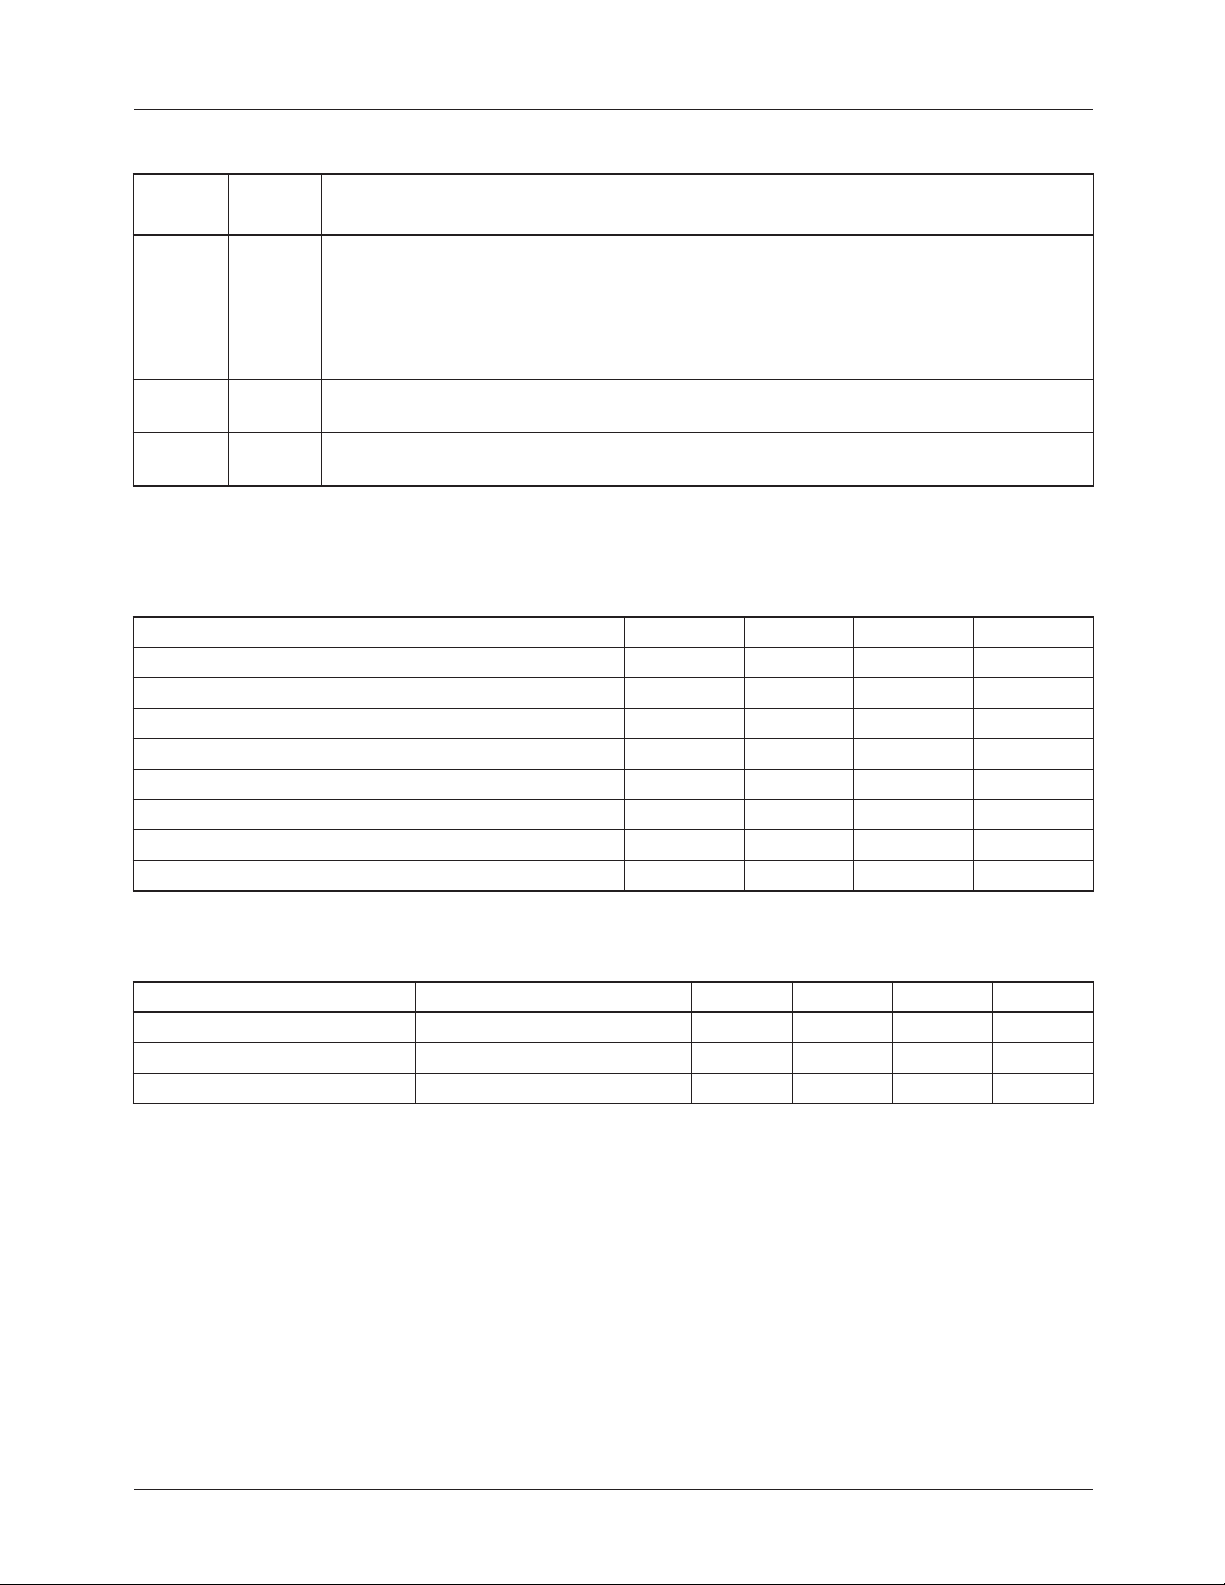
28 VCC VCC. This pin powers the chip. The IC starts to operate when voltage on this pin exceeds
Pin
Name
(continued)
Pin Function Description
Soft Start. A capacitor from this pin to GND programs the slew rate of the converter during
initialization as well as in operation. This pin is used as the reference against which the
output is compared. During initialization, this pin is charged with a 25 µ A current source.
Once this pin reaches 0.5V, its function changes, and it assumes the value of the voltage
as set by the VID programming. The current driving this pin is then limited to ±500 µ A, that
together with C
Input voltage from battery. This voltage is used by the oscillator for feed-forward
compensation of input voltage variation.
4.6V (UVLO rising) and shuts down when it drops below 4.3V (UVLO falling).
sets a controlled slew rate for VID code changes.
SS
Absolute Maximum Ratings
Absolute maximum ratings are the values beyond which the device may be damaged or have its useful life
impaired. Functional operation under these conditions is not implied.
Parameter Min. Typ. Max. Units
VCC Supply Voltage: 6.5 V
VIN 27 V
BOOT, SW, HDRV Pins 33 V
BOOT to SW 6.5 V
All Other Pins –0.3 VCC+0.3 V
Junction Temperature (T
Storage Temperature –65 150 °C
Lead Soldering Temperature, 10 seconds 300 °C
) –10 150 °C
J
Recommended Operating Conditions
Parameter Conditions Min. Typ. Max. Units
Supply Voltage VCC 4.75 5 5.25 V
Supply Voltage VIN 6 24 V
Ambient Temperature (T
4
) –20 85 °C
A
REV. 1.1.7 8/29/02
Page 5
µ
µ
µ
µ
µ
Ω
Ω
Ω
Ω
µ
µ
PRODUCT SPECIFICATION FAN5240
µ
Electrical Specifications
(VCC = 5V, VIN = 6V–24V, and T
unless otherwise noted.)
Parameter
Power Supplies
VCC Current Operating, C
VIN Current Operating 25
UVLO Threshold Rising VCC 4.3 4.45 4.6 V
Regulator / Control Functions
Output voltage per Table 2 0.925 2.00 V
Error Amplifier Gain 86 dB
Error Amplifier GBW 2.7 MHz
Error Amplifier Slew Rate 1 V/ µ S
VCORE+ Input Current 25 30 35
ILIM Voltage R
ILIM T
HOLDOFF
Over-voltage Threshold 2.2 2.35 2.5 V
Over-voltage Protection delay 2
EN, input threshold Logic LOW 0.8 V
Phase to Phase current mismatch IC contribution only
Over-Temperature Shut-down 150 °C
Over-Temperature Hysteresis 25 °C
Output Drivers
(note 1)
HDRV Output Resistance Sourcing 3.8 5
LDRV Output Resistance Sourcing 3.8 5
Oscillator
Frequency 255 300 345 KHz
Ramp Amplitude, pk–pk VIN = 16V 2 V
Ramp Offset 0.5 V
Ramp Gain 125 mV/V
Reference, DAC and Soft-Start
VID input threshold Logic LOW 0.8 V
VID pull-up current to VCC 1
DAC output accuracy –11%
Soft Start Charging current (I
Note 1: Guaranteed by slew rate testing.
= recommended operating ambient temperature range using circuit of Figure 1,
A
Conditions Min. Typ. Max. Units
= 10pF 2 mA
L
Shut-down (EN=0) 1 10
Shut-down (EN=0) 1
Falling VCC 3.8 3.95 4.10 V
ILIM
C
DELAY
= 30K Ω
= 22nF 1.16 mS
0.89 0.91 V
Logic HIGH 2 V
±5 %
Guaranteed by design
Sinking 1.6 3
Sinking 0.8 1.5
RampAmplitude
----------------------------------------------
V
IN
Logic HIGH 2.0 V
)V
SS
< 90% of Programmed output 20 27 34
SS
V
> 90% of Programmed output 350 500 650
SS
A
A
A
A
S
A
A
A
REV. 1.1.7 8/29/02
5
Page 6
µ
FAN5240 PRODUCT SPECIFICATION
Electrical Specifications
Parameter
(continued)
Conditions Min. Typ. Max. Units
PGOOD
VCORE Lower Threshold Falling Edge 800 825 850 mV
Rising Edge 850 875 900 mV
PGOOD Output Delay Low to High, C
PGOOD Output Low I
Leakage Current V
EN
POR/UVLO
SS
'
VOUT
PGOOD
VIN
EA1
ISNS1+ISNS2
5
VCORE+
30mA
VCORE-
DAC
Soft Start &
OVP
OSC
RAMP CLK
DUTY
CYCLE
CLAMP
ISNS1-ISNS2
A1
= 4mA 0.5 V
PGOOD
= 5V 1
PULLUP
HYST
Q
SR
PWM
A2
ISNS2-ISNS1
= 22nF 12 mS
DELAY
5V
VDD
HYST
FPWM
PWM
A
VOUT '
B
TO PH 2
MODULATOR
PWM/HYST
ILIM
MODE
det.
CURRENT
PROCESSING
ISNS1
ISNS2
S/H
VDD
I
LIM
ILIM
R
BOOT
HDRV
SW
LDRV
PGND
ISNS1
ISNS2
Q1
Q2
R
R
C
VIN
SENSE1
SENSE2
BOOT
VCORE
L
OUT
+
C
OUT
A
1K
R6
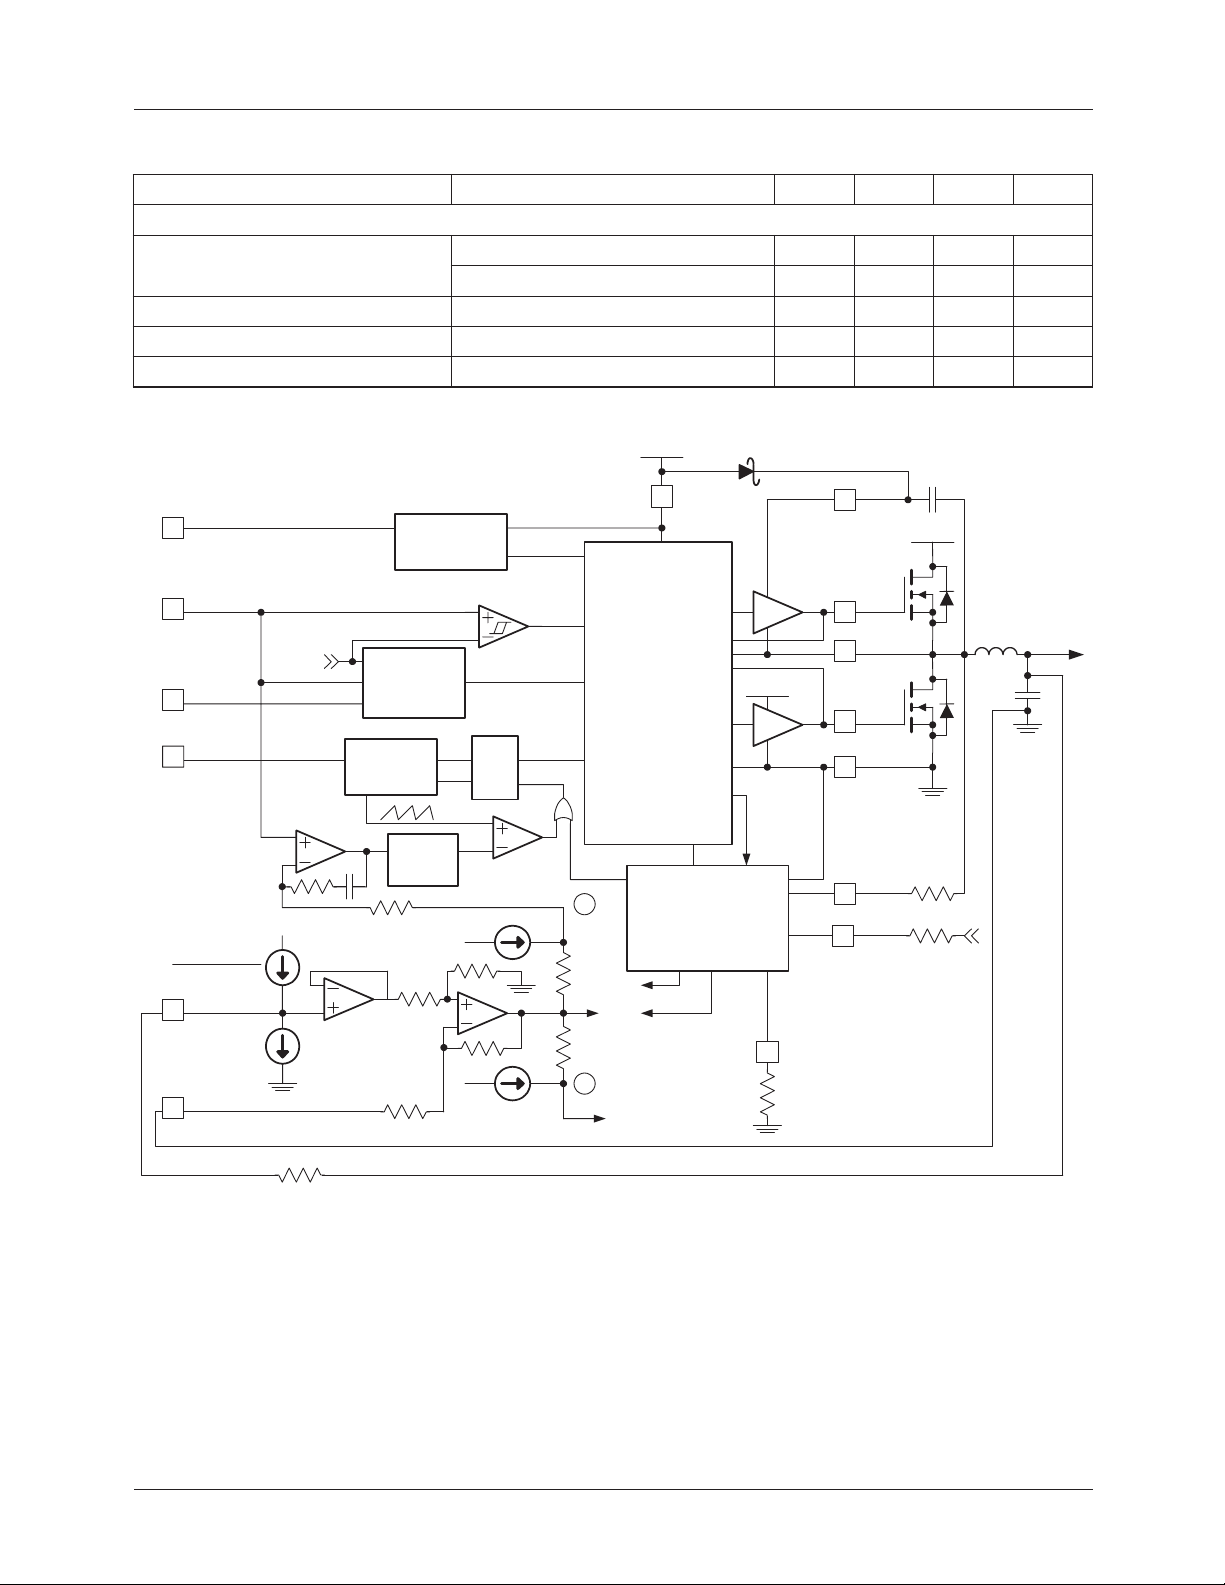
Figure 2. IC Block Diagram
6
REV. 1.1.7 8/29/02
Page 7
PRODUCT SPECIFICATION FAN5240
Circuit Description
Overview
The FAN5240 is a 2-phase, single output power management
IC, which supplies the low-voltage, high-current power to
modern processors for notebook PCs. Using very few external components, the IC controls a precision programmable
synchronous buck converter driving external N-Channel
power MOSFETs. The output voltage is adjustable from
0.925V to 2.0V by changing the DAC (VID) code settings
(see Table 2). The output voltage of the core converter can be
changed on-the-fly with programmable slew rate, which
meets a key requirement of AMD's Mobile Athlon/Duron
processors.
The converter can operate in two modes: fixed frequency
PWM, and variable frequency hysteretic depending on the
load. At loads lower than the point where filter inductor current becomes discontinuous, hysteretic mode of operation is
activated. Switchover from PWM to hysteretic operation at
light loads improves the converter's efficiency and prolongs
battery run time. As the filter inductor resumes continuous
current, the PWM mode of operation is restored.
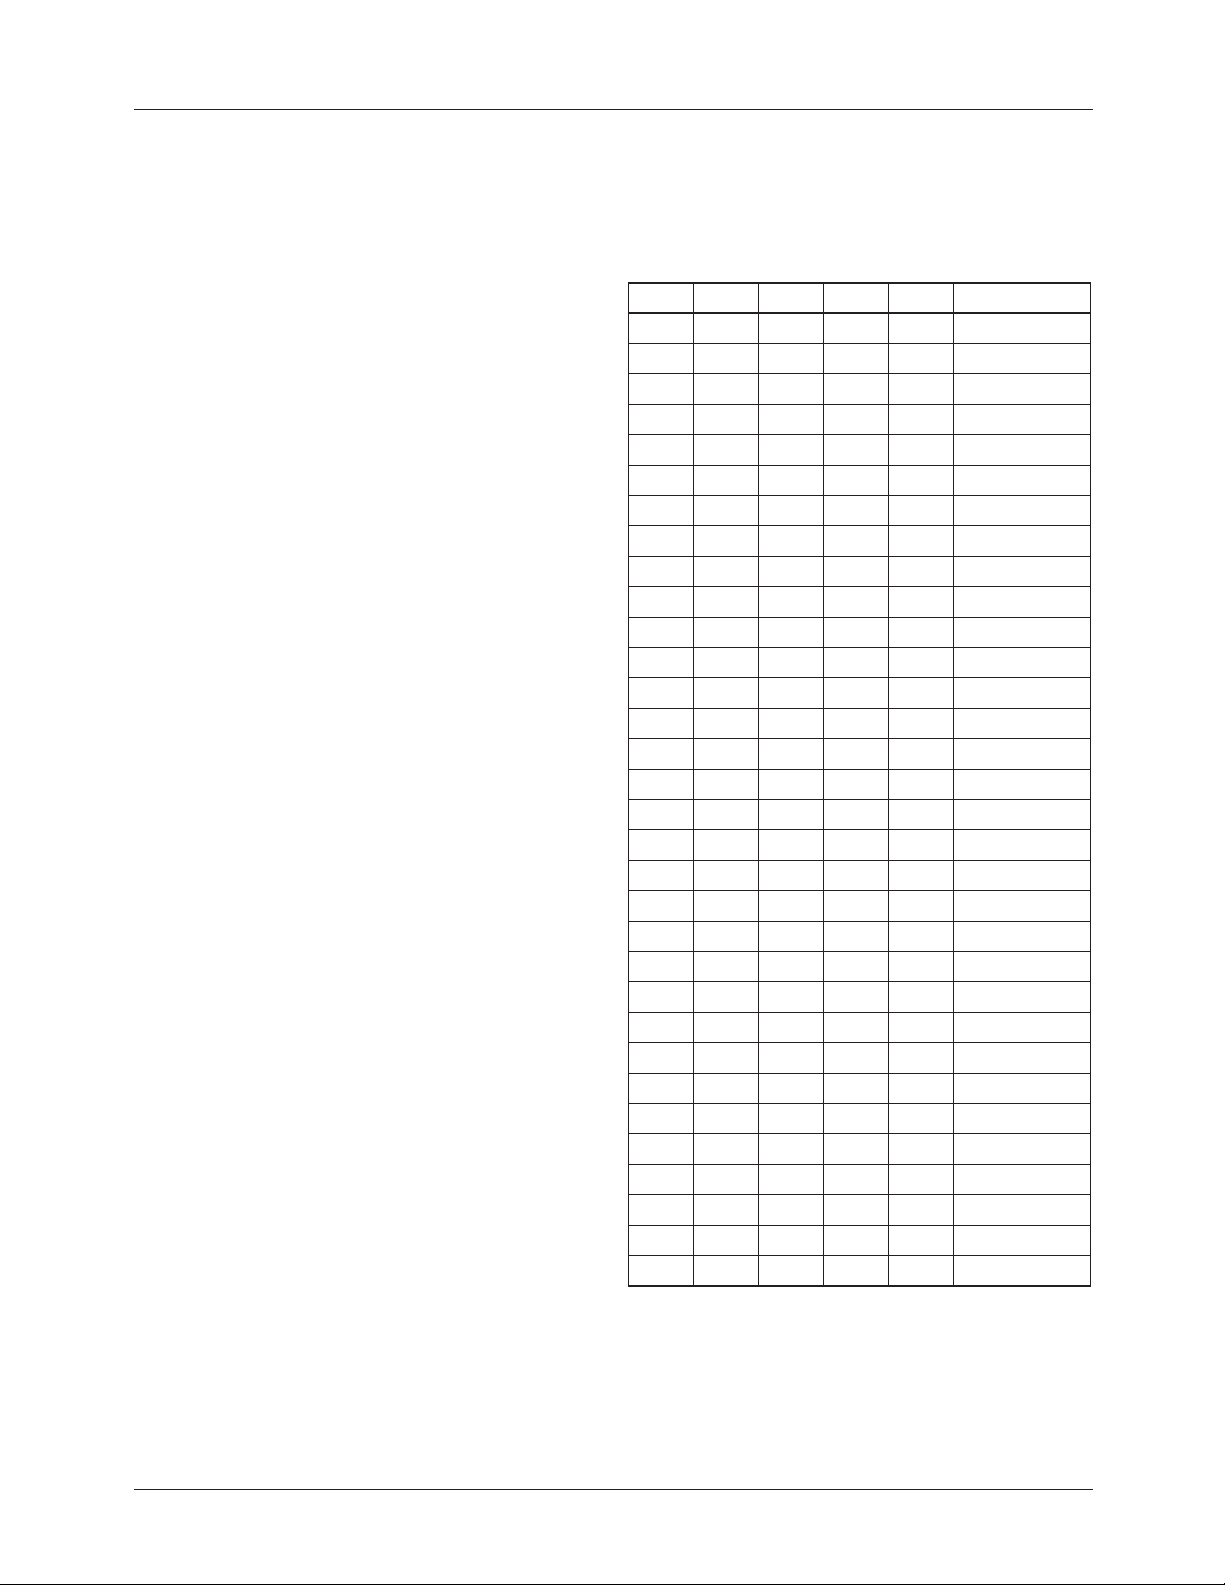
Output Voltage Programming
The output voltage of the converter is programmed by an
internal DAC in discrete steps of 25mV from 0.925V to
1.300V and then in 50mV steps from 1.300V to 2.00V:
Table 2. Output voltage VID
VID4 VID3 VID2 VID1 VID0 VOUT to CPU
11111 0.000
11110 0.925
11101 0.950
11100 0.975
11011 1.000
11010 1.025
11001 1.050
11000 1.075
10111 1.100
10110 1.125
10101 1.150
10100 1.175
10011 1.200
10010 1.225
10001 1.250
10000 1.275
01111 0.000
01110 1.300
01101 1.350
01100 1.400
01011 1.450
01010 1.500
01001 1.550
01000 1.600
00111 1.650
00110 1.700
00101 1.750
00100 1.800
00011 1.850
00010 1.900
00001 1.950
00000 2.000
REV. 1.1.7 8/29/02
1 - Logic High or open, 0 = Logic Low
VID0–4 pins will assume a logic 1 level if left open as each
input is pulled up with a 1 µ A internal current source.
7
Page 8
FAN5240 PRODUCT SPECIFICATION
Initialization, Soft Start and PGOOD
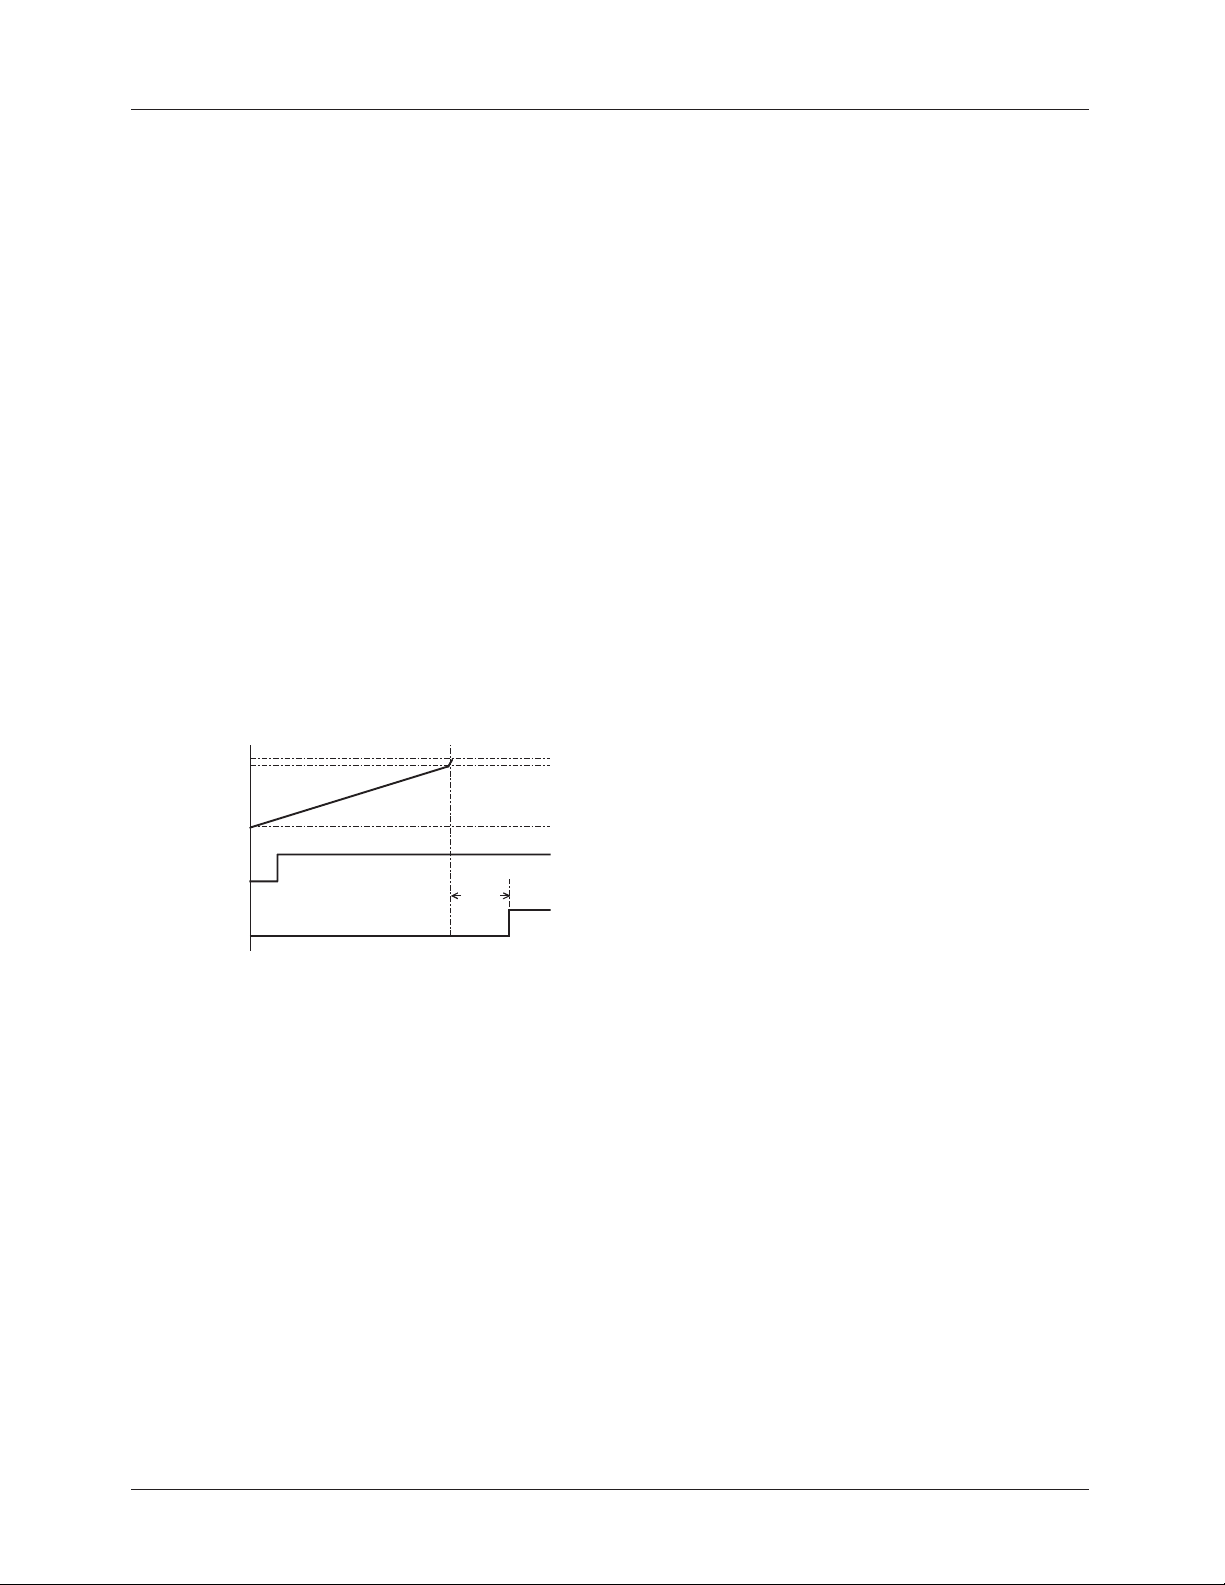
Assuming EN is high, FAN5240 is initialized when power is
applied on VCC. Should VCC drop below the UVLO threshold, an internal Power-On Reset function disables the chip.
The IC attempts to regulate the VCORE output according to
the voltage that appears on the SS pin (V
of the converter, this voltage is initially 0, and rises linearly
to 90% of the VID programmed voltage via the current supplied to C
by the 25 µ A internal current source. The time it
SS
takes to reach this threshold is:
0.9 V
× CSS×
VID
T
where T
--------------------------------------------=
90%
is in seconds if C
90%
25
is in µF.
SS
At that point, the current source changes to 500µA, which
establishes the slew rate of voltage changes at the output in
response to changes in VID.
This dual slope approach helps to provide safe rise of voltages and currents in the converters during initial start-up and
at the same time sets a controlled speed of the core voltage
change when the processor commands to do so.
1.
5V
V
1.35
SS
EN
PGOOD
Figure 3. Soft-Start function
CSS typically is chosen based on the slew rate desired in
response to a VID change. For example, if the spec requires a
500mV step to occur in 100µS:
I
SS
------------------
C
SS
∆V
DAC
500µA
-------------------
∆t
500mV
Assuming VID is set to 1.5V, with this value of C
time for the output voltage to rise to 0.9 of V
using equation 1:
T
1.35V 0.1×
------------------------------ 5.4mS==
90%
25
The transition from 90% VID to 100% VID occupies 0.5%
of the total soft-start time, so TSS is essentially T
). During start-up
SS
TDLY
100µS 0.1µF== =
, the
SS
is found
VID
.
90%
(1)
(2)
The PGOOD delay (TDLY, Figure 3) can be programmed
with a capacitor to GND on pin 16 (C
C
For 12mS of TDLY, C
C
DELAY
in nF()1.8 TDLY in mS()×=
DELAY
= 22nF.
DELAY
is typically chosen to provide 1mS of "blanking"
DELAY
):
(3)
for the over-current shut-down (see Over-Current Sensing,
on page 12).
The following conditions set the PGOOD pin low:
1. Under-voltage - VCORE is below a fixed voltage.
2. Chip shut-down due to over-temperature or over-current
as defined below.
Converter Operation (see Figure 2)
At nominal current the converter operates in fixed frequency
PWM mode. The output voltage is compared with a reference voltage set by the DAC, which appears on the SS pin.
The derived error signal is amplified by an internally compensated error amplifier and applied to the inverting input
of the PWM comparator. To provide output voltage droop for
enhanced dynamic load regulation, a signal proportional to
the output current is added to the voltage feedback signal
at the + input of A1. Since the processor specifies a +100mV/
-50mV tolerance on VCORE, a fixed positive offset of 30
mV is created with a 30µA current source and external 1K
resistor. Phase load balancing is accomplished by adding
a signal proportional to the difference of the two phase
currents before the error amplifier (at nodes A and B). This
feedback scheme in conjunction with a PWM ramp proportional to the input voltage allows for fast and stable loop
response over a wide range of input voltage and output
current variations. For the sake of efficiency and maximum
simplicity, the current sense signal is derived from the voltage drop across the lower MOSFET during its conduction
time. This current sense signal is used to set droop levels as
well as for phase balancing and current limiting.
The PWM controller has a built-in duty cycle clamp in the
path from the error amplifier to the PWM comparator.
During a severe load step, the output signal from the error
amp can go to its rail, pushing the duty cycle to almost 100%
for a significant amount of time. This could cause a severe
rise in the inductor current, especially at high battery voltage, and lead to a long recovery time or even failure of the
converter. To prevent this, the output of the error amplifier is
clamped to a fixed value after two clock cycles if a large
output voltage excursion is detected. Sensitivity of this
circuit is set in such a way as not to affect the PWM control
during transients normally expected from the load.
8
REV. 1.1.7 8/29/02
Page 9
PRODUCT SPECIFICATION FAN5240
Operation Mode Control
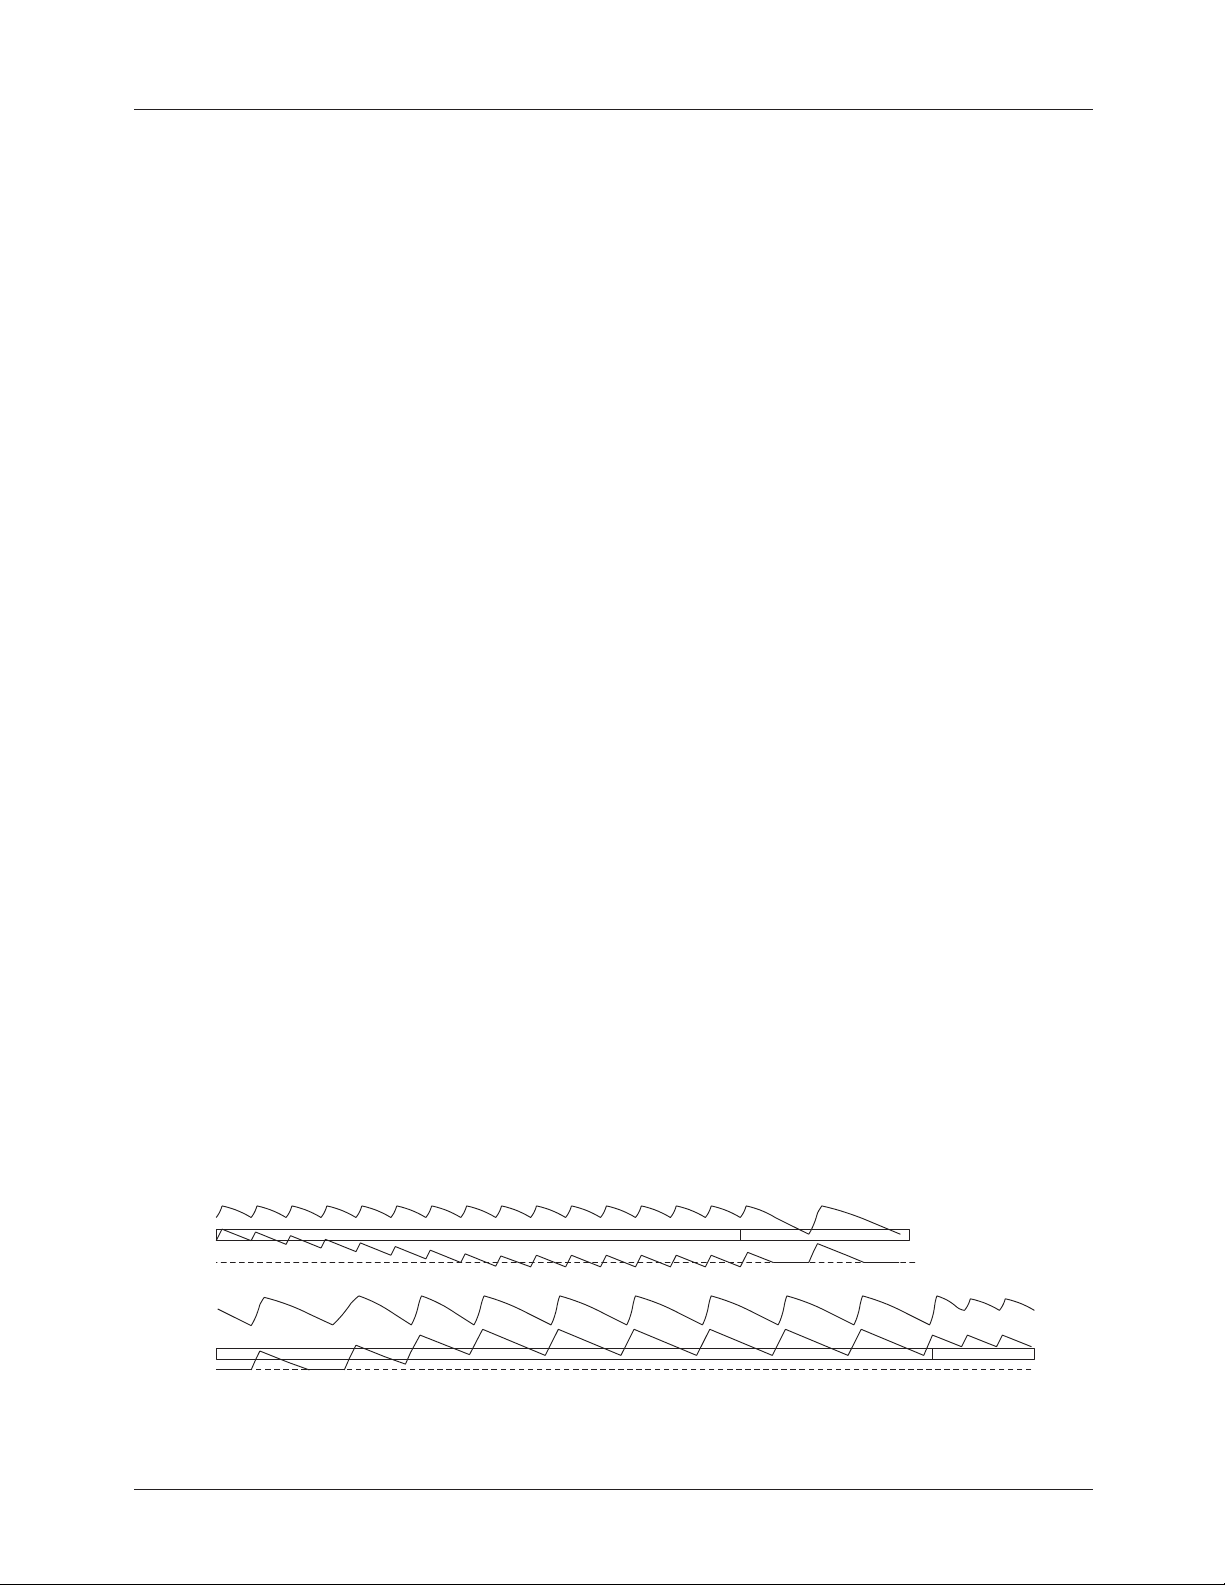
The mode-control circuit changes the converter’s mode of
operation from PWM to Hysteretic and visa versa, based
on the voltage polarity of the SW node when the lower
MOSFET is conducting and just before the upper MOSFET
turns on. For continuous inductor current, the SW node is
negative when the lower MOSFET is conducting and the
converters operate in fixed-frequency PWM mode as shown
in Figure 4. This mode of operation achieves high efficiency
at nominal load. When the load current decreases to the point
where the inductor current flows through the lower MOSFET
in the ‘reverse’ direction, the SW node becomes positive,
and the mode is changed to hysteretic, which achieves higher
efficiency at low currents by decreasing the effective switching frequency.
To prevent accidental mode change or “mode chatter” the
transition from PWM to Hysteretic mode occurs when the
SW node is positive for eight consecutive clock cycles
(see Figure 4). The polarity of the SW node is sampled at the
end of the lower MOSFET's conduction time. At the transition between PWM and hysteretic mode both the upper and
lower MOSFETs are turned off. The phase node will ‘ring’
based on the output inductor and the parasitic capacitance on
the phase node and settle out at the value of the output voltage.
The boundary value of inductor current, where current
becomes discontinuous, can be estimated by the following
expression.
VINV
–()V
OUT
I
LOAD DIS()
--------------------------------------------------=
2FSWL
OUTVIN
OUT
(4)
Hysteretic Mode
Conversely, the transition from Hysteretic mode to PWM
mode occurs when the SW node is negative for 8 consecutive
cycles.
A sudden increase in the output current will also cause a
change from hysteretic to PWM mode. This load increase
causes an instantaneous decrease in the output voltage due to
the voltage drop on the output capacitor ESR. If the load
causes the output voltage (as presented at VSNS) to drop
below the hysteretic regulation level (20mV below VREF),
the mode is changed to PWM on the next clock cycle. This
insures the full power required by the increase in output
current.
In hysteretic mode, the PWM comparator and the error
amplifier that provide control in PWM mode are inhibited
and the hysteretic comparator is activated. In hysteretic
mode the low side MOSFET is operated as a synchronous
rectifier, where the voltage across V
and its gate switched off when V
DS(ON
is monitored,
DS(ON)
) goes positive
(current flowing back from the load) blocking reverse
conduction
The hysteretic comparator initiates a PFM signal to turn on
HDRV when the output voltage (at VSNS) falls below the
lower threshold (10mV below VREF) and terminates the
PFM signal when VSNS rises over the higher threshold
(5mV above VREF).
The switching frequency is primarily a function of:
1. Spread between the two hysteretic thresholds
2. I
LOAD
3. Output Inductor and Capacitor ESR
A transition back to PWM (Continuous Conduction Mode or
CCM) mode occurs when the inductor current rises sufficiently to stay positive for 8 consecutive cycles. This occurs
when:
∆V
HYSTERESIS
I
LOAD CCM()
where ∆V
HYSTERESIS
series resistance of C
-----------------------------------------=
2 ESR
= 15mV and ESR is the equivalent
.
OUT
(5)
Because of the different control mechanisms, the value of the
load current where transition into CCM operation takes place
is typically higher compared to the load level at which transition into hysteretic mode occurs.
V
CORE
I
L
0
V
CORE
I
L
0
REV. 1.1.7 8/29/02 9
12 3 4 5 6 7 8
Figure 4. Transitioning between PWM and Hysteretic Mode
12345678
Hysteretic ModePWM Mode
PWM ModeHysteretic Mode
Page 10
FAN5240 PRODUCT SPECIFICATION
Current Processing Section
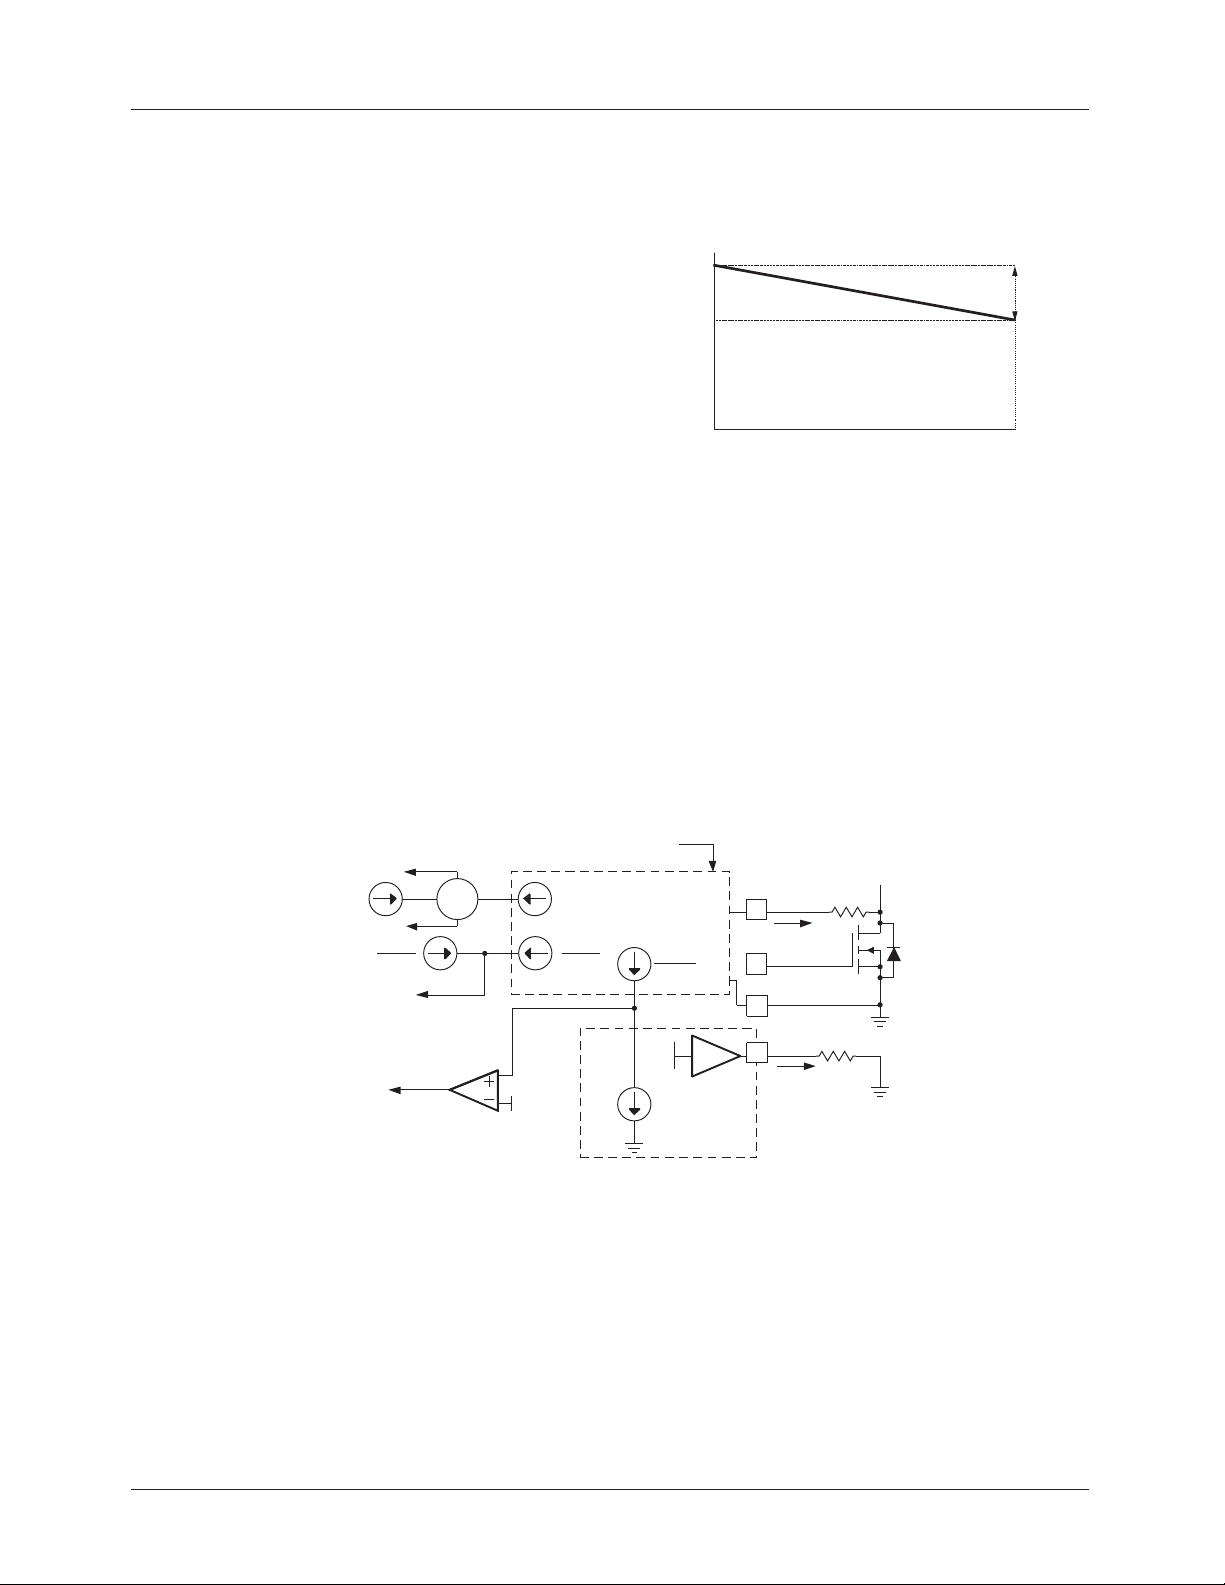
The following discussion refers to Figure 6.
Setting RSENSE
Each phase current is sampled about 200nS after the SW
node crosses 0V. For proper converter operation, choose an
RSENSE value of:
R
SENSE
R
-----------------------------------------=
•
DS ON()IMAX
40µA
which is about 1K for the components in Figure 1.
Active Droop
The core converter incorporates a proprietary output voltage
droop method for optimum handling of fast load transients
found in modern processors.
“Active droop” or voltage positioning is now widely used in
the computer power applications. The technique is based on
raising the converter voltage at light load in anticipation of a
step increase in load current, and conversely, lowering
VCORE in anticipation of a step decrease in load current.
With Active Droop, the output voltage varies with the load as
if a resistor were connected in series with the converter’s output, in other words, it's effect is to raise the output resistance
of the converter.
1.2
V
DROOP
CORE
V
I
LOAD
I
MAX
Figure 5. Active Droop
To get the most from the Active Droop, its magnitude should
be scaled to match the output capacitor’s ESR voltage drop.
V
DROOPIMAX
ESR×=
(6)
Active Droop allows the size and cost of the output capacitors required to handle CPU current transients to be reduced.
The reduction may be almost a factor of 2 when compared to
a system without Active Droop.
ISNS1-ISNS
ISNS2-ISNS1
ISNS2
To A1 (+)
ILIM det. 1
H
S/
V to I
1ISNS2
ISNS1
0.9V
I2 = ILIM
in +
8
in D
ILIM mirror
2
5
B-A
A B
Σ
A-B
ISNS
ISNS1
5
2.5V
Figure 6. Current Limit and Active Droop Circuits
ISNS1
LDRV1
PGND1
ILIM
R
SENSE
R
ILIM
10 REV. 1.1.7 8/29/02
Page 11
PRODUCT SPECIFICATION FAN5240
Additionally, the CPU power dissipation is also slightly
reduced as it is proportional to the applied voltage squared
and even slight voltage decrease translates to a measurable
reduction in power dissipated.
ILOAD
V
ES
upper lim
V
ES
upper lim
lower lim
Vout
(no droop)
Vout
droop ≈ ESR
lower lim
Figure 7. Effect of Active Droop on ESR
The processor regulation window including transients is
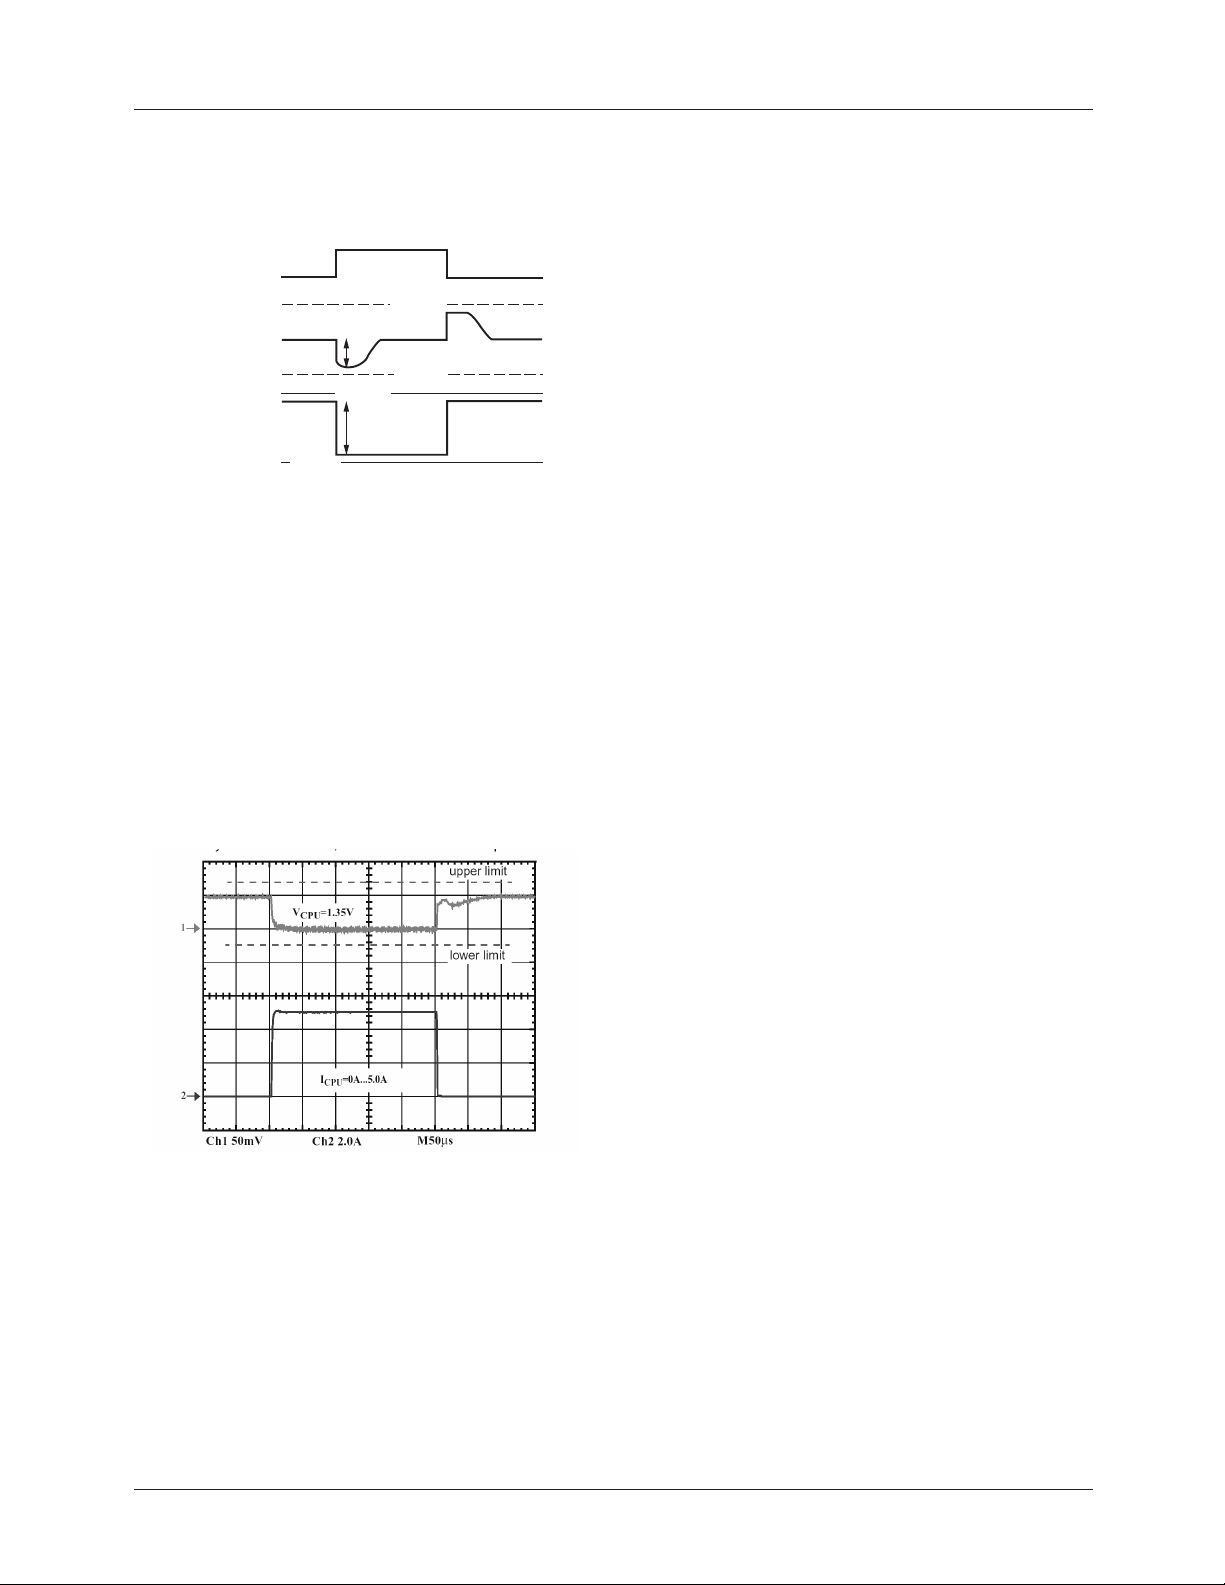
specified as +100mV..–50mV. To accommodate the droop,
the output voltage of the converter is raised by about 30mV
at no load.
The converter response to the load step is shown in Figure 8.
At zero load current, the output voltage is raised ~30mV
above nominal value of 1.5V. When the load current
increases, the output voltage droops down approximately
55mV. Due to use of Active Droop, the converter’s output
voltage adaptively changes with the load current allowing
better utilization of the regulation window.
The current through each R
resistor (ISNS) is sam-
SENSE
pled shortly after LDRV is turned on. That current is held for
the remainder of the cycle, and then injected to produce an
offset to VCORE+ through the external 1K resistor (R6 in
Figure 1). This creates a voltage at the input to the error
amplifier that rises with increasing current, causing the regulator’s output to droop as the current increases.
I
•
LOADRDS ON()
V
DROOP
--------------------------------------------=
3R
•
SENSE
(7)
Gate Driver section
The gate control logic translates the internal PWM control
signal into the MOSFET gate drive signals providing
necessary amplification, level shifting and shoot-through
protection. Also, it has functions that help optimize the IC
performance over a wide range of operating conditions.
Since MOSFET switching time can vary dramatically from
type to type and with the input voltage, the gate control logic
provides adaptive dead time by monitoring the gate-tosource voltages of both upper and lower MOSFETs. The
lower MOSFET drive is not turned on until the gate-tosource voltage of the upper MOSFET has decreased to less
than approximately 1 volt. Similarly, the upper MOSFET is
not turned on until the gate-to-source voltage of the lower
MOSFET has decreased to less than approximately 1 volt.
This allows a wide variety of upper and lower MOSFETs to
be used without a concern for simultaneous conduction, or
shoot-through.
There must be a low – resistance, low – inductance path
between the driver pin and the MOSFET gate for the adaptive dead-time circuit to work properly. Any delay along that
path will subtract from the delay generated by the adaptive
dead-time circit and a shoot-through condition may occur.
Frequency Loop Compensation
Due to the implemented current mode control, the modulator
has a single pole response with -1 slope at frequency determined by load
------------------------=
2πR
1
OCO
(8)
F
PO
Figure 8. Converter response to 5A load step
where RO is load resistance, CO is load capacitance. For this
type of modulator Type 2 compensation circuit is usually
sufficient. To reduce the number of external components and
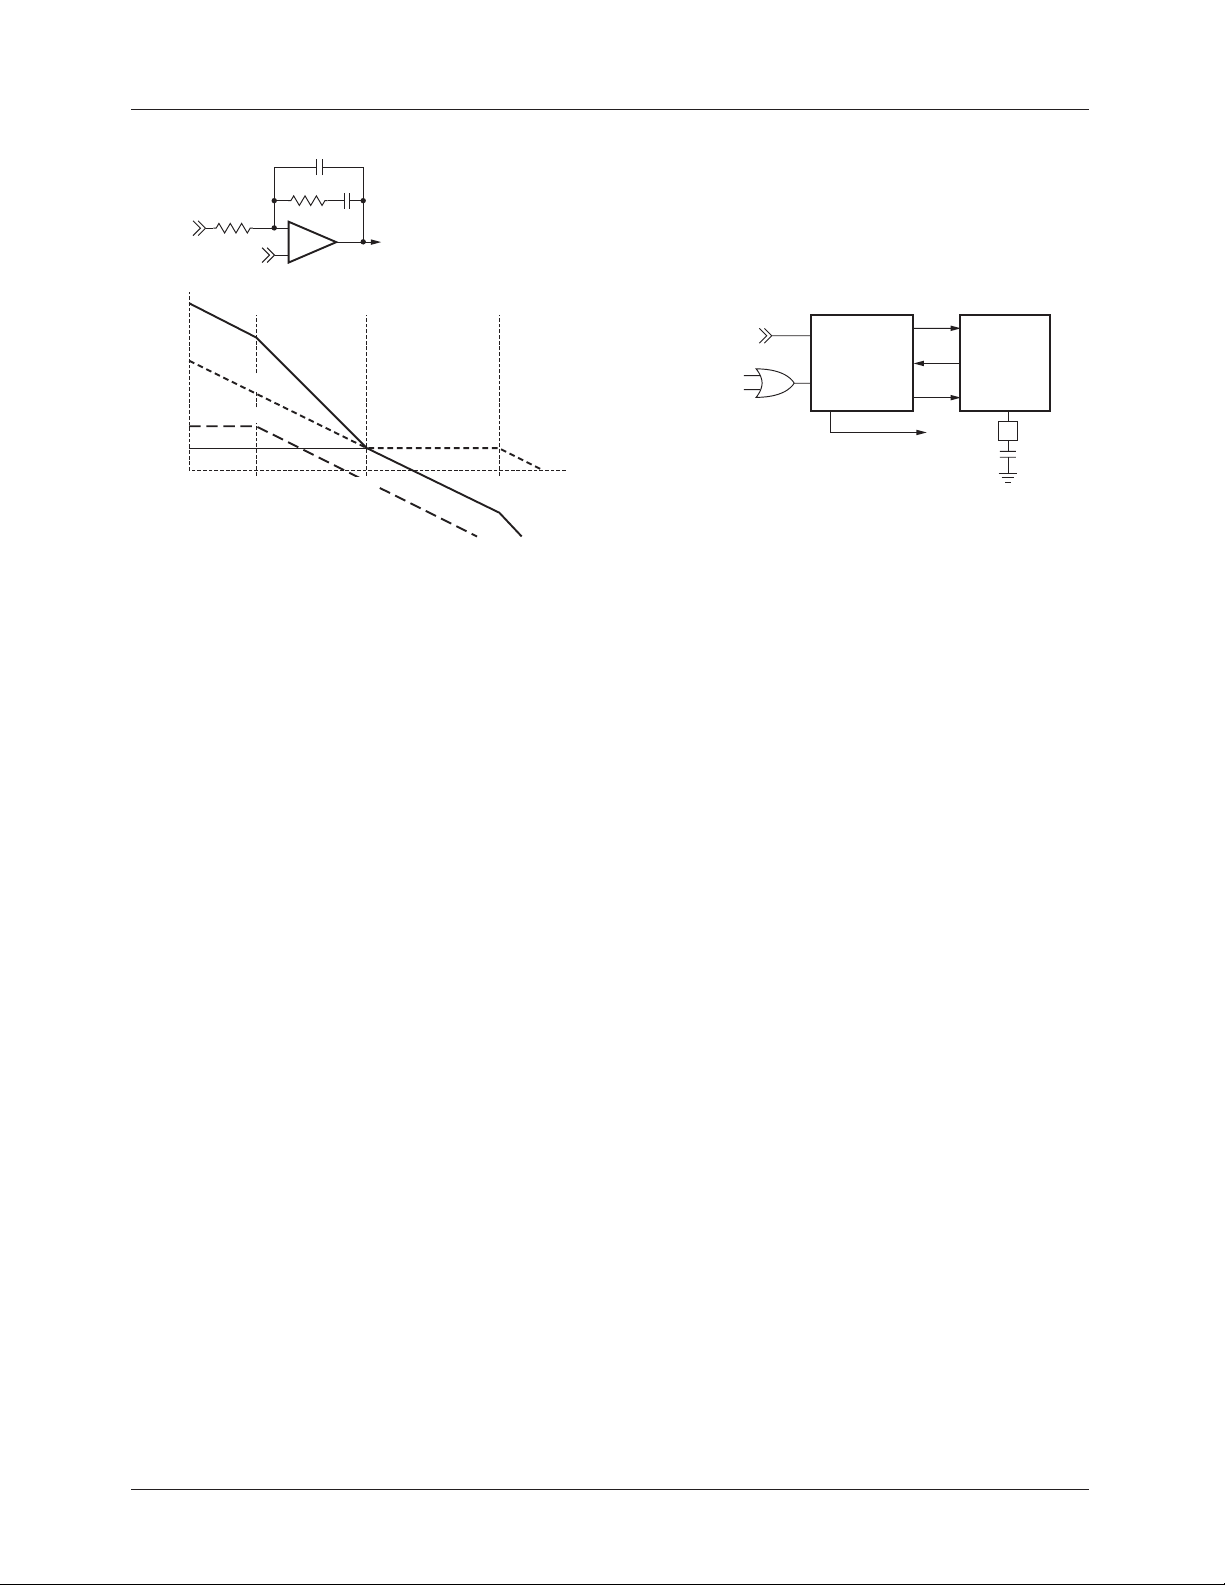
simplify the design task, the PWM controller has an internally compensated error amplifier. Figure 9 shows a Type 2
amplifier and its response along with the responses of a current mode modulator and of the converter. The Type 2 amplifier, in addition to the pole at the origin, has a zero-pole pair
that causes a flat gain region at frequencies between the zero
and the pole.
REV. 1.1.7 8/29/02 11
Page 12
FAN5240 PRODUCT SPECIFICATION
V
IN
Modulator
18
14
0
R1
–
REF
Error Amp
F
Z
F
P
+
Converter
F
P0
Figure 9. Compensation
1
---------------------- 6 kHz==
2πR
2C1
1
---------------------- 600 kHz==
2πR
2C2
R2
C2
C1
EAOut
F
Z
Over-Current sensing (see Figure 10)
When the circuit's current limit signal (“ILIM det” as shown
in Figure 6) goes high, a pulse-skipping circuit is activated
and a 16-clock cycle counter is started. HDRV will be inhibited as long as the sensed current is higher than the ILIM
value. This limits the current supplied by the DC input.
DELAY
DELAY
RESET
Q TIMER
START
.
(10)
Clock
ILIM det. 1
ILIM det. 2
F
P
Figure 10. Over-current shut-down delay logic
16 Clock
Counter and
Logic
Shut-down
If ILIM det goes high during counts 9-16 of the counter, the
overcurrent delay timer is started and the 16-clock counter
starts again. This timer delays the shut-down of the chip and
(9a)
(9b)
its time is a function of the value of C
T
HOLDOFF
C
in mS()
---------------------------------------=
DELAY
in nF()
19
This region is also associated with phase ‘bump’ or reduced
phase shift. The amount of phase shift reduction depends on
how wide the region of flat gain is and has a maximum value
of 90 degrees. To further simplify the converter compensation, the modulator gain is kept independent of the input
voltage variation by providing feed-forward of VIN to the
oscillator ramp.
The zero frequency, the amplifier high frequency gain and
the modulator gain are chosen to satisfy most typical applications. The crossover frequency will appear at the point
where the modulator attenuation equals the amplifier high
frequency gain. The only task that the system designer has to
complete is to specify the output filter capacitors to position
the load main pole somewhere within one decade lower than
the amplifier zero frequency. With this type of compensation
plenty of phase margin is easily achieved due to zero-pole
pair phase ‘boost’.
Conditional stability may occur only when the main load
pole is positioned too much to the left side on the frequency
axis due to excessive output filter capacitance. In this case,
the ESR zero placed within the 10kHz...50kHz range gives
some additional phase ‘boost’. Fortunately, there is an opposite trend in mobile applications to keep the output capacitor
as small as possible.
Protection
The converter output is monitored and protected against
short circuit (over-current), and over-voltage conditions.
Over-current must detected at least once during the first 8
clock cycles and once during the 2nd 8 clock cycles of the
16-cycle counter for the timer to continue timing. If the overcurrent condition does not occur at least once per 8 clock
counts during any clock counter cycle while the timer is
high, the timer and the over-current detection circuit are
reset, preventing shutdown. The clock counter coutinues to
count and look for ILIM det pulses in this manner until
either:
1. the IC is shut-down because the timer timed out:
If the timer pulse is allowed to finish by timing out, the
IC is shut-down and can only be restarted by removing
power or toggling the EN pin.
2. ILIM det does not go high at least once per 8 clock
counts. In this case, the timer and over-current shutdown
logic are reset, and a chip shut-down is averted.
PGOOD will go LOW if the IC shuts down from overcurrent.
Setting the Current Limit
ISNS is compared to the current established when a 0.9 V
internal reference drives the ILIM pin. The threshold is
determined at the point when the
I
ISNS
---------------
0.9V
--------------
> ISNS
8
R
ILIM
. Since
•
LOADRDS ON()
--------------------------------------------=
R
SENSE
therefore,
8R
R
ILIM
0.9V
---------------
I
LIMIT
()•
SENSE
-----------------------------------
×=
R
DS ON()
(11)
12 REV. 1.1.7 8/29/02
Page 13
PRODUCT SPECIFICATION FAN5240
Since the tolerance on the current limit is largely dependent
on the ratio of the external resistors it is fairly accurate if the
voltage drop on the Switching Node side of R
SENSE
is an
accurate representation of the load current. When using the
MOSFET as the sensing element, the variation of R
DS(ON)
causes proportional variation in the ISNS. This value not
only varies from device to device, but also has a typical
junction temperature coefficient of about 0.4% / °C (consult
the MOSFET datasheet for actual values), so the actual
current limit set point will decrease propotional to increasing
MOSFET die temperature. The same discussion applies to
the V
calculation.
DROOP
Q2
LDRV
R
SENSE
ISNS
21
R1
PGND
22
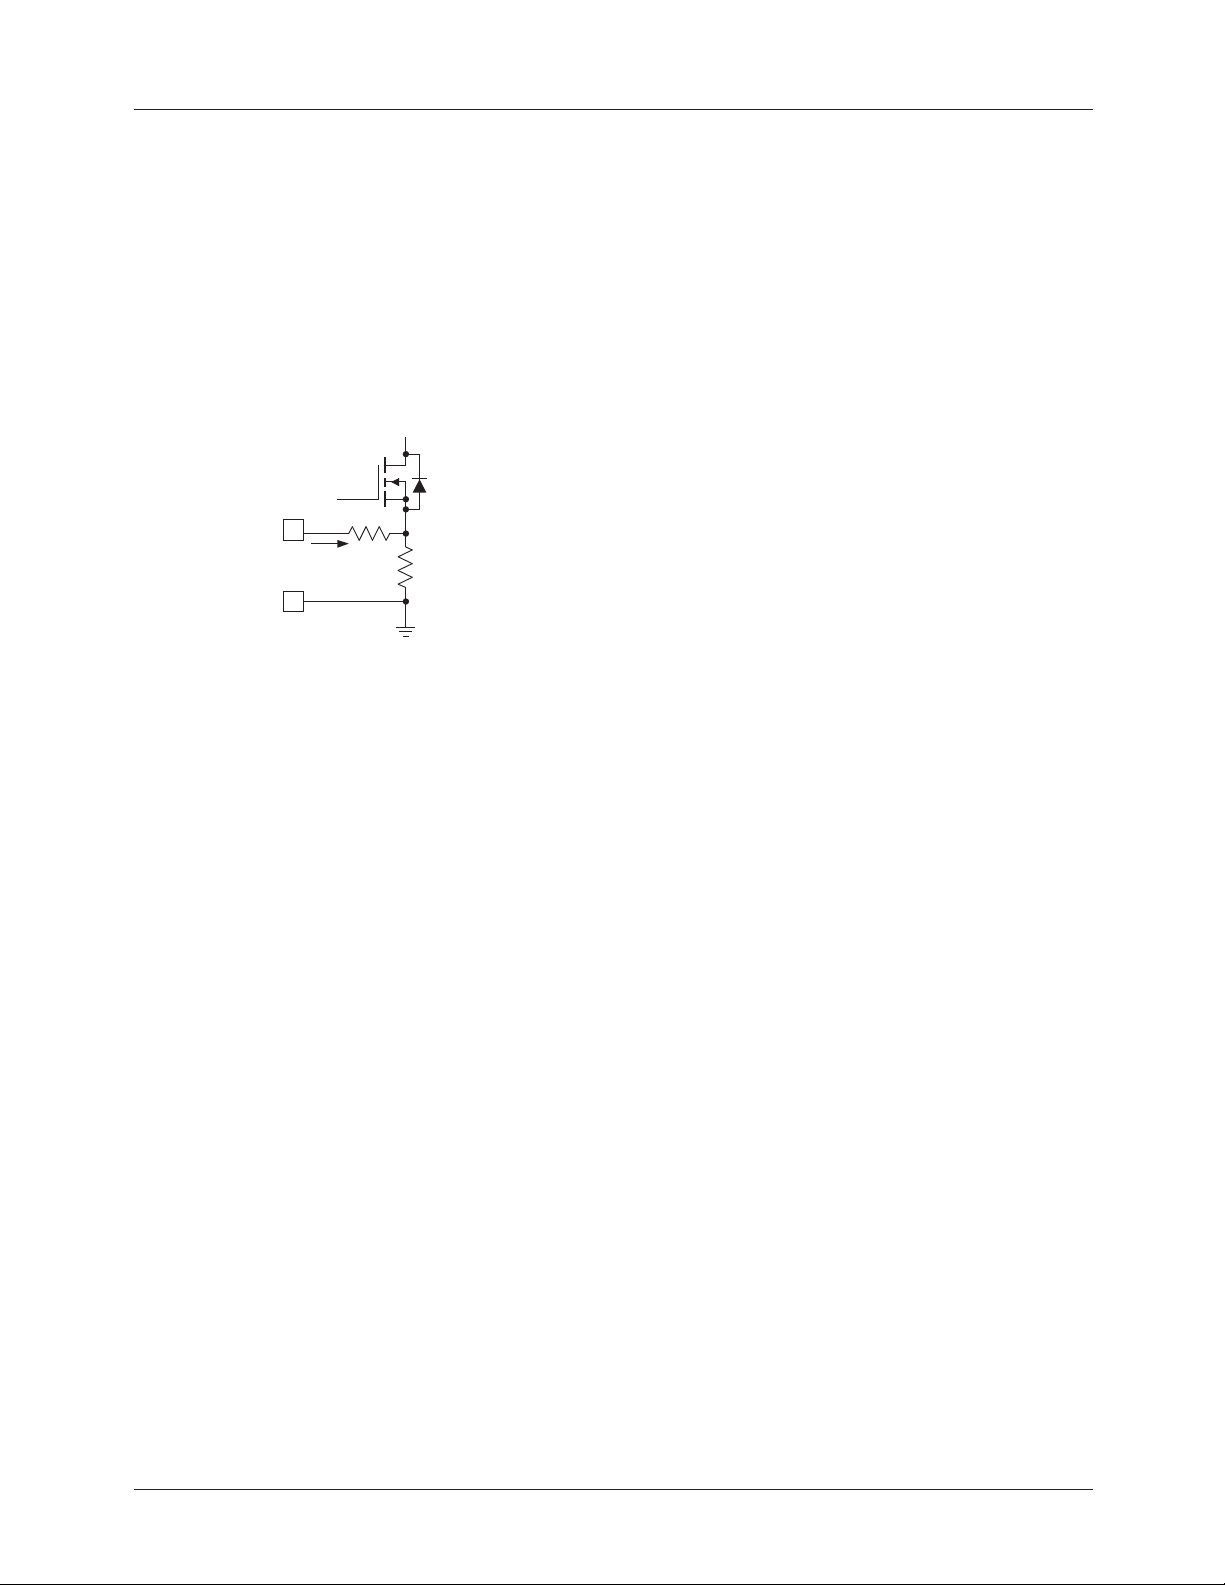
Figure 11. Improving current sensing accuracy
More accurate sensing can be achieved by using a resistor
(R1) instead of the R
of the FET as shown in Figure
DS(ON)
11. This approach causes higher losses, but yields greater
accuracy in both V
DROOP
and I
. R1 is a low value
LIMIT
(e.g. 10mΩ) resistor.
The current limit (I
) set point chosen needs to accom-
LIMIT
modate ripple current, slew current, and variability in the
MOSFET's R
I
LIMITILOAD
> C
DS(ON)
.
dV
-------
+
OUT
dt
(12a)
The over-current comparator is sampled just after LDRV is
turned on, when the current is near its peak in the cycle.
Assuming 20% inductor ripple current, we can then add 1/2
of the ripple current, or 10%. An additional factor of 1.2
accounts for the inaccuracy in the initial (room temperature)
R
accommodate the rise of the MOSFET R
ating with T
12.5A/phase, the target for I
so using equation 11, with R
FDS6688 MOSFETs, R
of the MOSFETs with an additional factor of 1.4 to
DS(ON)
DS(ON)
@ 125°C. With a maximum load current of
J
(per phase) would be:
LIMIT
I
LIMIT
1.1 1.2• 1.4• 12.5A
•> 42A≈ (12c)
DS(ON)
≈ 56K:
ILIM
20A
-----------+
2
= 3mΩ for the 2 parallel
Over-Voltage Protection
Should the output voltage exceed 2.35V due to an upper
MOSFET failure, or for other reasons, the overvoltage
protection comparator will force the LDRV high. This action
actively pulls down the output voltage and, in the event of
the upper MOSFET failure, will eventually blow the battery
fuse. As soon as the output voltage drops below the threshold, the OVP comparator is disengaged.
This OVP scheme provides a ‘soft’ crowbar function which
helps to tackle severe load transients and does not invert the
output voltage when activated — a common problem for
OVP schemes with a latch.
Over-Temperature Protection
The chip incorporates an over temperature protection circuit
that shuts the chip down when a die temperature of 150°C is
reached. Normal operation is restored at die temperature
below 125°C with internal Power On Reset asserted, resulting in a full soft-start cycle.
when oper-
dV
-------
Slew current ( ) is the current required for the
C
OUT
dt
output voltage to slew upwards during VID code changes,
since the circuit will limit the regulator’s output current by
dV
pulse skipping when I
is reached. The term we
LIMIT
-------
dt
used earlier in the discussion (set up by the CSS) was
500mV/100µS or 5V/mS. Assuming C
current required to slew C
dV
-------
C
OUT
4mF 5V/mS• 20A==
dt
at this rate is:
OUT
of 4000µF, the
OUT
(12b)
which is contributed roughly equally from each phase,
therefore, 1/2 of the slew current comes from a single phase.
REV. 1.1.7 8/29/02 13
Page 14
FAN5240 PRODUCT SPECIFICATION
Design and Component Selection
Guidelines
As an initial step, define operating voltage range and minimum and maximum load currents for the controller. For this
discussion,
IOUT Max 25A
VIN 5.5 to 21 V
VOUT 0.925 to 2 V
Output Inductor Selection
The minimum practical output inductor value is the one that
keeps inductor current just on the boundary of continuous
conduction at some minimum load. The industry standard
practice is to choose the ripple current to be somewhere from
15% to 35% of the nominal current. At light load, the ripple
current also determines the point where the converter will
automatically switch to hysteretic mode of operation (I
to sustain high efficiency. The following equations help to
choose the proper value of the output filter inductor.
∆V
OUT
,
∆I2I
×
MIN
------------------==
ESR
where ∆I is the inductor ripple current, which we will choose
for 20% of the full load current (12.5A in each phase) and
∆V
is the maximum output ripple voltage allowed.
OUT
L
V
–
INVOUT
------------------------------
F
SW
V
OUT
--------------
×=
∆I×
V
IN
MIN
(13)
The load transient requirements are a function of the slew
rate (di/dt) and the magnitude of the transient load current.
Modern microprocessors produce transient load rates in
excess of 10A/µs. High frequency ceramic capacitors placed
beneath the processor socket initially supply the transient
and reduce the slew rate seen by the bulk capacitors. The
bulk capacitor values are generally determined by the total
allowable ESR rather than actual capacitance requirements.
High frequency decoupling capacitors should be placed as
close to the processor power pins as physically possible.
Consult with the processor manufacturer for specific
decoupling requirements. Use only specialized low-ESR
electrolytic capacitors intended for switching-regulator
applications for the bulk capacitors. The bulk capacitor’s
ESR will determine the output ripple voltage and the initial
voltage drop after a transient. In most cases, multiple electrolytic capacitors of small case size perform better than a
single large case capacitor.
)
Input Capacitor Selection
The input capacitor should be selected by its ripple current
rating. For a 2 phase converter, the RMS currents is calculated:
I
PK
--------
I
RMS
2
2D 4D
This equation produces the worst case value at maximum
duty cycle. For our example, that occurs when VIN = 5.5V
and VOUT = 2V. For 25A maximum output the maximum
RMS current at CIN:
2
–=
(14)
for this example we’ll use:
VIN = 20V, V
OUT
= 1.5V
∆I = 20% *12.5A (per phase) = 2.5A
FSW = 300KHz.
Therefore,
L ≈ 1.8µH
The inductor's current rating should be chosen per the
I
calculated above. Some transient currents over the
LIMIT
inductor current rating may be tolerable if the inductor’s
dL
saturation characteristic is sufficiently “soft”.
-------
dI
Output Capacitor Selection
The output capacitor serves two major functions in a switching power supply. Along with the inductor it filters the
sequence of pulses produced by the switcher, and it supplies
the load transient currents. The filtering requirements are a
function of the switching frequency and the ripple current
allowed, and are usually easy to satisfy in high frequency
converters.
I
RMS MAX()
5.6A=
Power MOSFET Selection
For the example in the following discussion, we will be
selecting components for:
VIN from 5V to 20V
V
= 1.5V @ I
OUT
LOAD(MAX)
The FAN5240 converter’s output voltage is very low with
respect to the input voltage, therefore the Lower MOSFET
(Q2) is conducting the full load current for most of the cycle.
Therefore, Q2 should be selected to be a MOSFET with low
R
DS(ON)
to minimize conduction losses.
In contrast, Q1 is on for a maximum of 20% (when VIN =
5V) of the cycle, and its conduction loss will have less of an
impact. Q1, however, sees most of the switching losses, so
Q1’s primary selection criteria should be gate charge
(Q
G(SW)
).
= 12.5A/phase
14 REV. 1.1.7 8/29/02
Page 15
PRODUCT SPECIFICATION FAN5240
High-Side Losses:
C
V
DS
I
D
V
GS
V
SP
V
TH
= C
C
ISS
GS
ISS
Q
GS
t1 t2 t3
|| C
GD
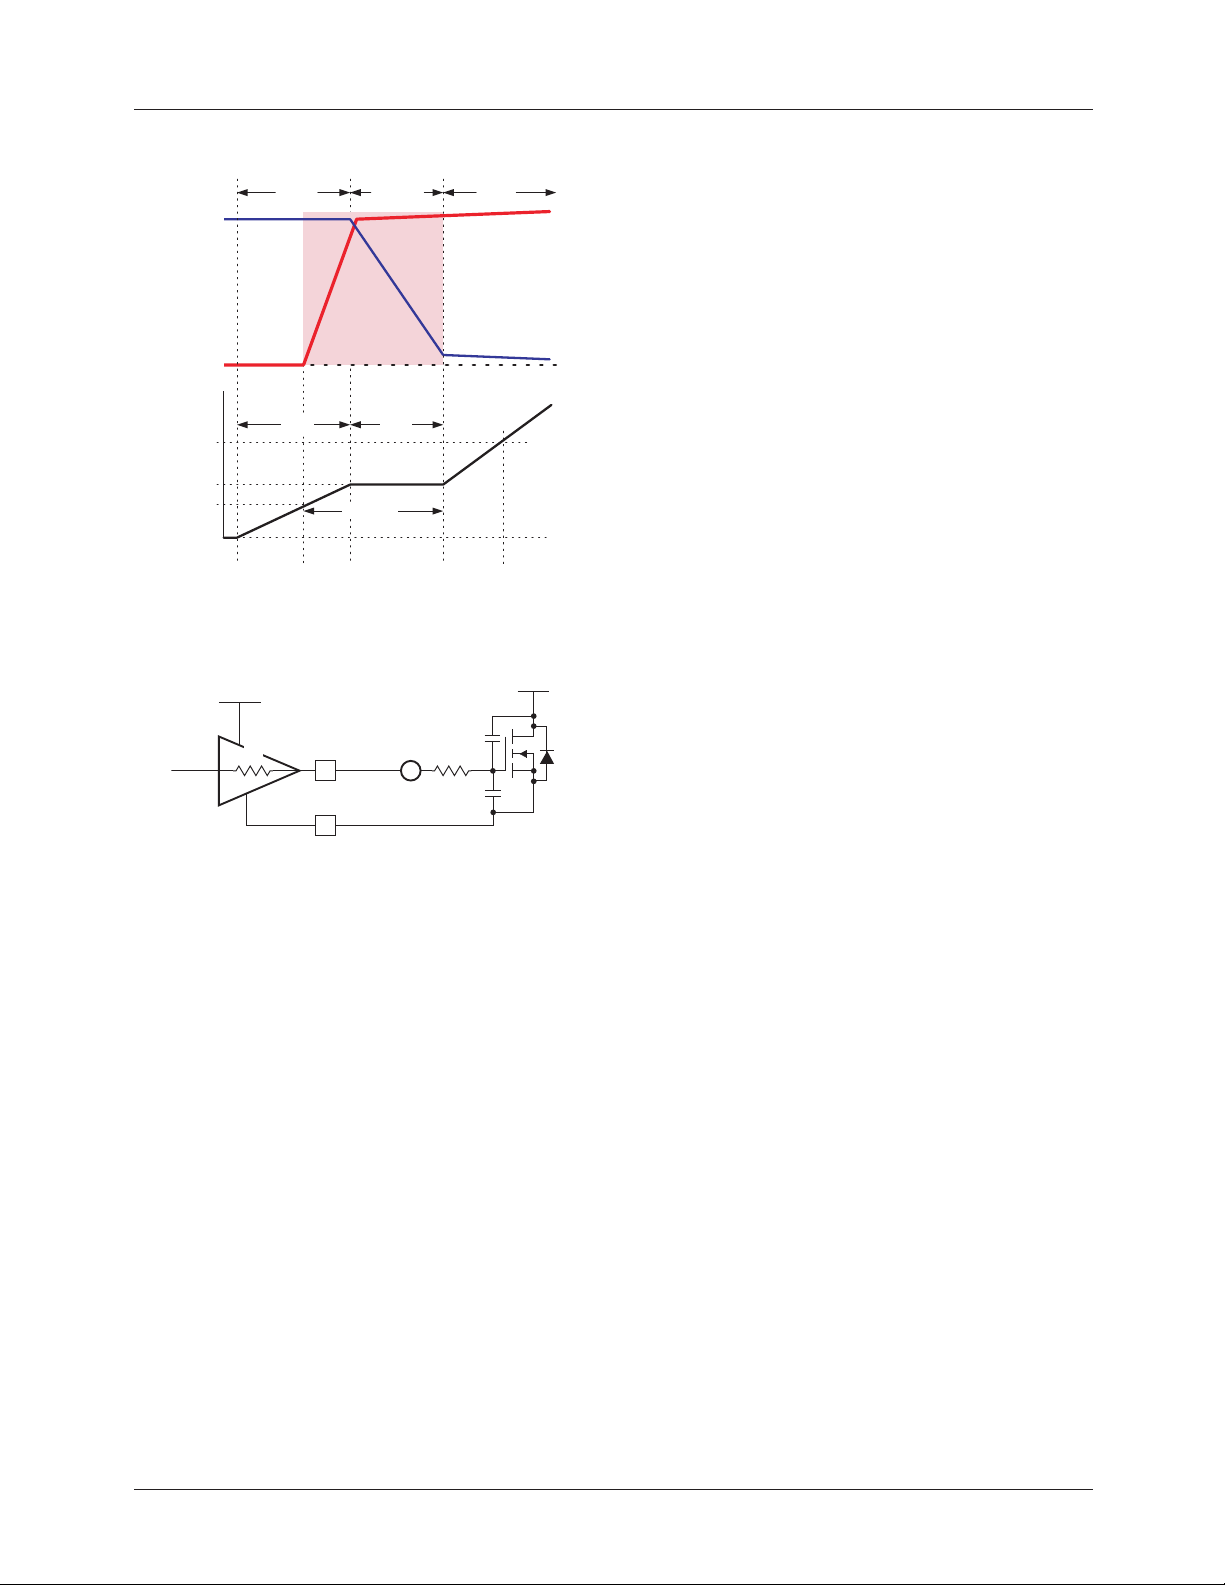
Figure 12. Switching losses and Q
5V
R
D
19
20
Figure 13. Drive Equivalent Circuit
Assuming switching losses are about the same for both the
rising edge and falling edge, Q1’s switching losses, as can be
seen by Figure 12, are given by:
P
UPPERPSWPCOND
+=
Q
G(SW)
HDRV
SW
C
R
GATE
C
C
ISS
t4 t5
G
C
GD
GS
VI
4.5V
N
RSS
Q
GD
G
(15a)
most of t
occurs when VGS = VSP we can use a constant
S
current assumption for the driver to simplify the calculation
:
of t
S
Q
GSW()
t
S
---------------------
I
≈=
DRIVER
For the high-side MOSFET, V
Q
------------------------------------------------------
GSW()
VDD VSP–
------------------------------------------------
R
+
DRIVERRGATE
= VIN, which can be as
DS
(16)
high as 20V in a typical portable application. Q2, however,
switches on or off with its parallel shottky diode conducting,
therefore VDS ≈ 0.5V. Since PSW is proportional to V
DS
,
Q2's switching losses are negligible and we can select Q2
based on R
DS(ON)
only.
Care should also be taken to include the delivery of the
MOSFET's gate power ( P
) in calculating the power
GATE
dissipation required for the FAN5240:
P
GATEQG
VDD FSW××=
(17)
Low-Side Losses
Conduction losses for Q2 are given by:
P
where R
COND
DS(ON)
1D–()I
is the R
highest operating junction temperature and is
2
× R
DS(ON)
×=
OUT
DS ON()
of the MOSFET at the
D
the minimum duty cycle for the converter. Since D
for portable computers, (1-D) ≈ 1, further simplifying the
calculation.
The maximum power dissipation (P
D(MAX)
) is a function of
the maximum allowable die temperature of the low-side
MOSFET, the θ
, and the maximum allowable ambient
J-A
temperature rise:
V
OUT
--------------=
V
MIN
IN
is 5%
(18)
VDSIL×
P
P
---------------------
=
SW
V
COND
--------------
2
OUT
V
IN
2× t
×
S
2
I
× R
OUT
F
SW
×=
DS ON()
(15b)
(15c)
P
D MAX()
θ
, depends primarily on the amount of PCB area that can
J-A
be devoted to heat sinking (see FSC app note AN-1029 for
T
-------------------------------------------------=
–
J MAX()TA MAX()
θ
JA–
SO-8 MOSFET thermal information).
where R
is the switching period (rise or fall time) and is predomi-
t
S
DS(ON)
is @T
J(MAX)
and:
nantly the sum of t2, t3 (Figure 12), a function of the impedance of the driver and the Q
REV. 1.1.7 8/29/02 15
of the MOSFET. Since
G(SW)
Page 16
FAN5240 PRODUCT SPECIFICATION
Layout Considerations
Switching converters, even during normal operation,
produce short pulses of current which could cause substantial ringing and be a source of EMI if layout constrains are
not observed.
There are two sets of critical components in a DC-DC
converter. The switching power components process large
amounts of energy at high rate and are noise generators.
The low power components responsible for bias and feedback functions are sensitive to noise.
A multi-layer printed circuit board is recommended.
Dedicate one solid layer for a ground plane. Dedicate
another solid layer as a power plane and break this plane
into smaller islands of common voltage levels.
Notice all the nodes that are subjected to high dV/dt voltage
swing such as SW, HDRV and LDRV, for example. All surrounding circuitry will tend to couple the signals from these
nodes through stray capacitance. Do not oversize copper
traces connected to these nodes. Do not place traces connected to the feedback components adjacent to these traces.
It is not recommended to use High Density Interconnect
Systems, or micro-vias on these signals. The use of blind or
buried vias should be limited to the low current signals only.
The use of normal thermal vias is left to the discretion of the
designer.
Keep the wiring traces from the IC to the MOSFET gate and
source as short as possible and capable of handling peak currents of 2A. Minimize the area within the gate-source path to
reduce stray inductance and eliminate parasitic ringing at the
gate.
Locate small critical components like the soft-start capacitor
and current sense resistors as close as possible to the respective pins of the IC.
The FAN5240 utilizes advanced packaging technology that
will have lead pitch of 0.6mm. High performance analog
semiconductors utilizing narrow lead spacing may require
special considerations in PWB design and manufacturing. It
is critical to maintain proper cleanliness of the area surrounding these devices. It is not recommended to use any
type of rosin or acid core solder, or the use of flux in either
the manufacturing or touch up process as these may contribute to corrosion or enable electromigration and/or eddy currents near the sensitive low current signals. When chemicals
such as these are used on or near the PWB, it is suggested
that the entire PWB be cleaned and dried completely before
applying power.
16 REV. 1.1.7 8/29/02
Page 17
PRODUCT SPECIFICATION FAN5240
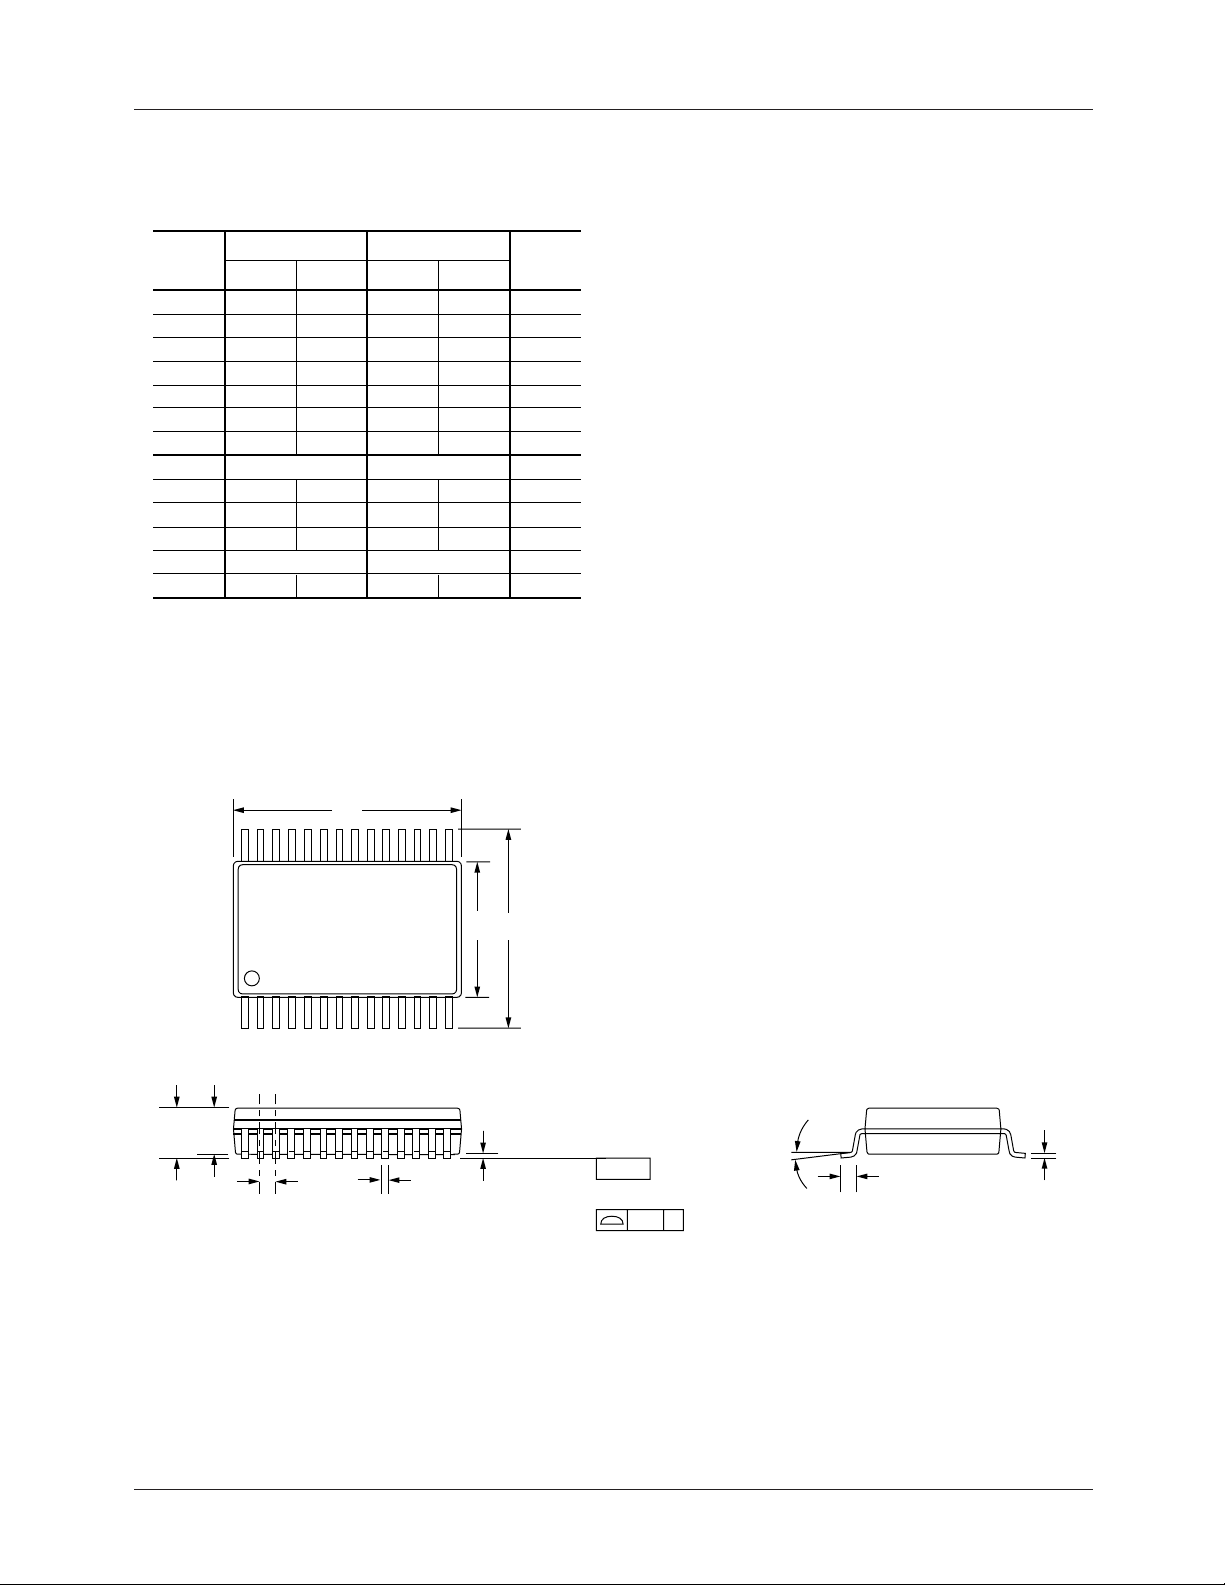
Mechanical Dimensions
28-Pin QSOP
Symbol
A 0.069 1.75
A1 0.004 0.10
A2 - -
B 0.008 0.012 0.20 0.30
C 0.007 0.010 0.18 0.25
D 0.386 0.394 9.81 10.00
E
e
H
h
L
N28 28
α
Inches
Min. Max. Min. Max.
0.053 1.35
0.010 0.25
0.061 1.54
0.150 0.157 3.81 3.98
0.025 BSC 0.635 BSC
0.228 0.244
0.0099 0.0196
0.016 0.050 0.41 1.27
0° 8° 0° 8°
D
Millimeters
5.80 6.19
0.26 0.49
Notes
9
3
4
5
6
7
Notes:
1.
Symbols are defined in the "MO Series Symbol List" in
Section 2.2 of Publication Number 95.
2.
Dimensioning and tolerancing per ANSI Y14.5M-1982.
3.
Dimension "D" does not include mold flash, protrusions
or gate burrs. Mold flash, protrusions shall not exceed
0.25mm (0.010 inch) per side.
4.
Dimension "E" does not include interlead flash or
protrusions. Interlead flash and protrusions shall not
exceed 0.25mm (0.010 inch) per side.
5.
The chamber on the body is optional. If it is not present,
a visual index feature must be located within the
crosshatched area.
6.
"L" is the length of terminal for soldering to a substrate.
7.
"N" is the maximum number of terminals.
8.
Terminal numbers are shown for reference only.
9.
Dimension "B" does not include dambar protrusion.
Allowable dambar protrusion shall be 0.10mm (0.004
inch) total in excess of "B" dimension at maximum
material condition.
10.
Controlling dimension: INCHES. Converted millimeter
dimensions are not necessarily exact.
A A2
E
H
A1
e
B
SEATING
PLANE
– C –
LEAD COPLANARITY
ccc C
α
L
C
REV. 1.1.7 8/29/02 17
Page 18
FAN5240 PRODUCT SPECIFICATION
Mechanical Dimensions
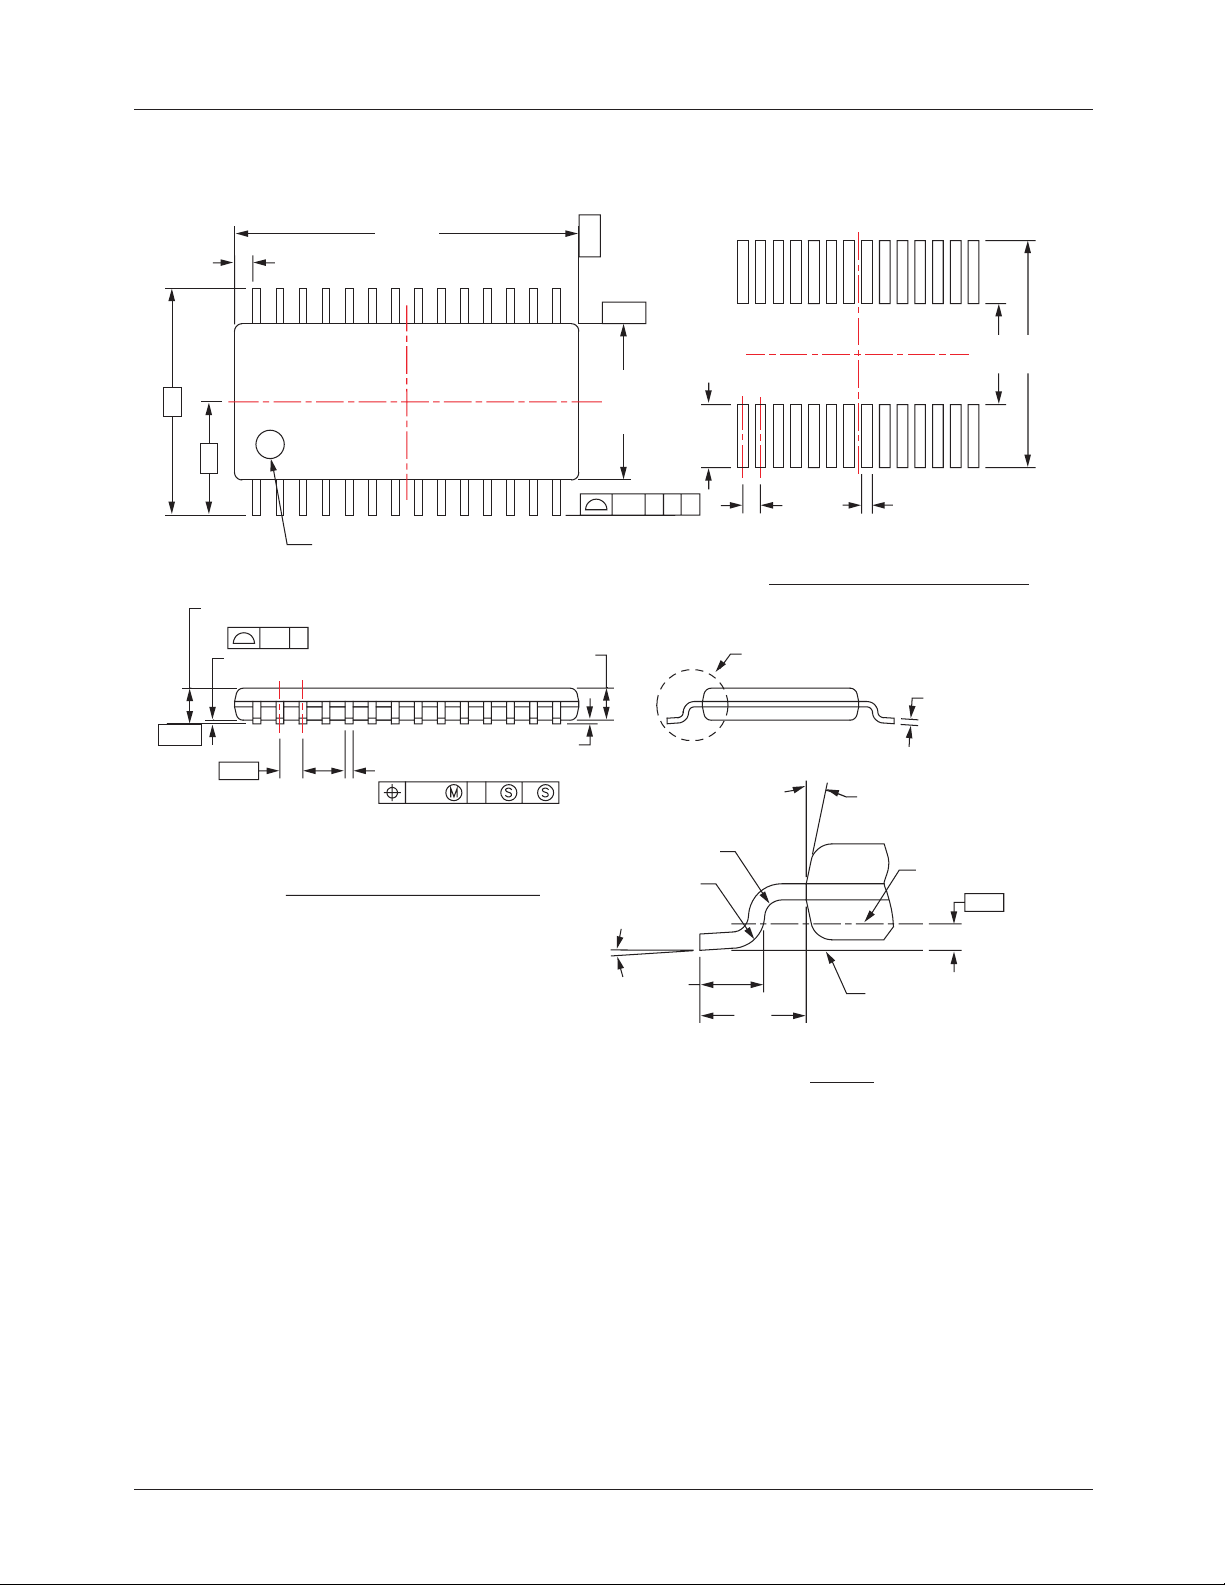
28-Pin TSSOP
0.51 TYP
28
9.7 ± 0.1
15
– A –
– B –
4.16
7.72
6.4
3.2
0.2
14
0.90
ALL Lead Tips
+0.15
–0.10
0°–8°
0.61 ± 0.1
PIN # 1 IDENT
1.2 MAX
0.1 C
ALL LEAD TIPS
– C –
0.65 0.19–0.30
0.13
DIMENSIONS ARE IN MILLIMETERS
NOTES:
A. Conforms to JEDEC registration MO-153, variation AB,
Ref. Note 6, dated 7/93.
B. Dimensions are in millimeters.
C. Dimensions are exclusive of burrs, mold flash, and tie bar extensions.
D Dimensions and Tolerances per ANsI Y14.5M, 1982
0.10 ± 0.05
BCA
4.4 ± 0.1
BA
R0.16
R0.31
1.78
0.65 0.42
LAND PATTERN RECOMMENDATION
See Detail A
0.09–0.20
12.00° Top & Botom
GAGE PLANE
.025
SEATING PLANE
1.00
DETAIL A
18 REV. 1.1.7 8/29/02
Page 19
FAN5240 PRODUCT SPECIFICATION
Ordering Information
Part Number Temperature Range Package Packing
FAN5240QSC -10°C to 85°C QSOP-28 Rails
FAN5240QSCX -10°C to 85°C QSOP-28 Tape and Reel
FAN5240MTC -10°C to 85°C TSSOP-28 Rails
FAN5240MTCX -10°C to 85°C TSSOP-28 Tape and Reel
DISCLAIMER
FAIRCHILD SEMICONDUCTOR RESERVES THE RIGHT TO MAKE CHANGES WITHOUT FURTHER NOTICE TO
ANY PRODUCTS HEREIN TO IMPROVE RELIABILITY, FUNCTION OR DESIGN. FAIRCHILD DOES NOT ASSUME
ANY LIABILITY ARISING OUT OF THE APPLICATION OR USE OF ANY PRODUCT OR CIRCUIT DESCRIBED HEREIN;
NEITHER DOES IT CONVEY ANY LICENSE UNDER ITS PATENT RIGHTS, NOR THE RIGHTS OF OTHERS.
LIFE SUPPORT POLICY
FAIRCHILD’S PRODUCTS ARE NOT AUTHORIZED FOR USE AS CRITICAL COMPONENTS IN LIFE SUPPORT DEVICES
OR SYSTEMS WITHOUT THE EXPRESS WRITTEN APPROVAL OF THE PRESIDENT OF FAIRCHILD SEMICONDUCTOR
CORPORATION. As used herein:
1. Life support devices or systems are devices or systems
which, (a) are intended for surgical implant into the body,
or (b) support or sustain life, and (c) whose failure to
perform when properly used in accordance with
instructions for use provided in the labeling, can be
reasonably expected to result in a significant injury of the
user.
www.fairchildsemi.com
2. A critical component in any component of a life support
device or system whose failure to perform can be
reasonably expected to cause the failure of the life support
device or system, or to affect its safety or effectiveness.
8/29/02 0.0m 003
2002 Fairchild Semiconductor Corporation
Stock#DS30005240
 Loading...