

Page 1
CMOS ST-BUS FAMILY
MT8930C
Subscriber Network Interface Circuit
Preliminary Information
Features
• ETS 300-012, CCITT I.430 and ANSI T1.605
S/T interface
• Full-duplex 2B+D, 192 kbit/s transmission
• Link activation/deactivation
• D-channel access contention resolution
• Point-to-point, point-to-multipoint and star
configurations
• Master (NT)/Slave (TE) modes of operation
• Exceeds loop length requirements
• Complete loopback testing capabilities
• On chip HDLC D-channel protocoller
• 8 bit Motorola/Intel microprocessor interface
• Controllerless or microprocessor-controlled
operation
• Mitel ST-BUS interface
• Low power CMOS technology
• Single 5 volt power supply
Applications
• ISDN NT1
• ISDN S or T interface
• ISDN Terminal Adaptor (TA)
• Digital sets (TE1) - 4 wire ISDN interface
• Digital PABXs, Digital Line Cards (NT2)
ISSUE 1 May 1995
Ordering Information
MT8930CC 28 Pin Ceramic DIP
MT8930CE 28 Pin Plastic DIP
MT8930CP 44 Pin PLCC
-40°C to +85°C
Description
The MT8930C Subscriber Network Interface Circuit
(SNIC) implements the ETSI ETS 300-012, CCITT
I.430 and ANSI T1.605 Recommendations for the
ISDN S and T reference points. Providing point-topoint and poin t-to-multipoi nt digital tran smission, th e
SNIC may be used at either end of the subscriber
line (NT or TE).
An HDLC D-channel protocoller is included and
controlled through a Motorola/Intel microprocessor
port. A controllerless mode allows the SNIC to
operate without a microprocessor.
The MT8930C is fabricated in Mitel’s CMOS
process.
DSTi
DSTo
F0od
C4b
F0b
STAR/Rsto
CK/NT
Cmode
Rsti
ST-BUS
Interface
PLL
Timing
and
Control
HALF AD0-7 R/W/WR,
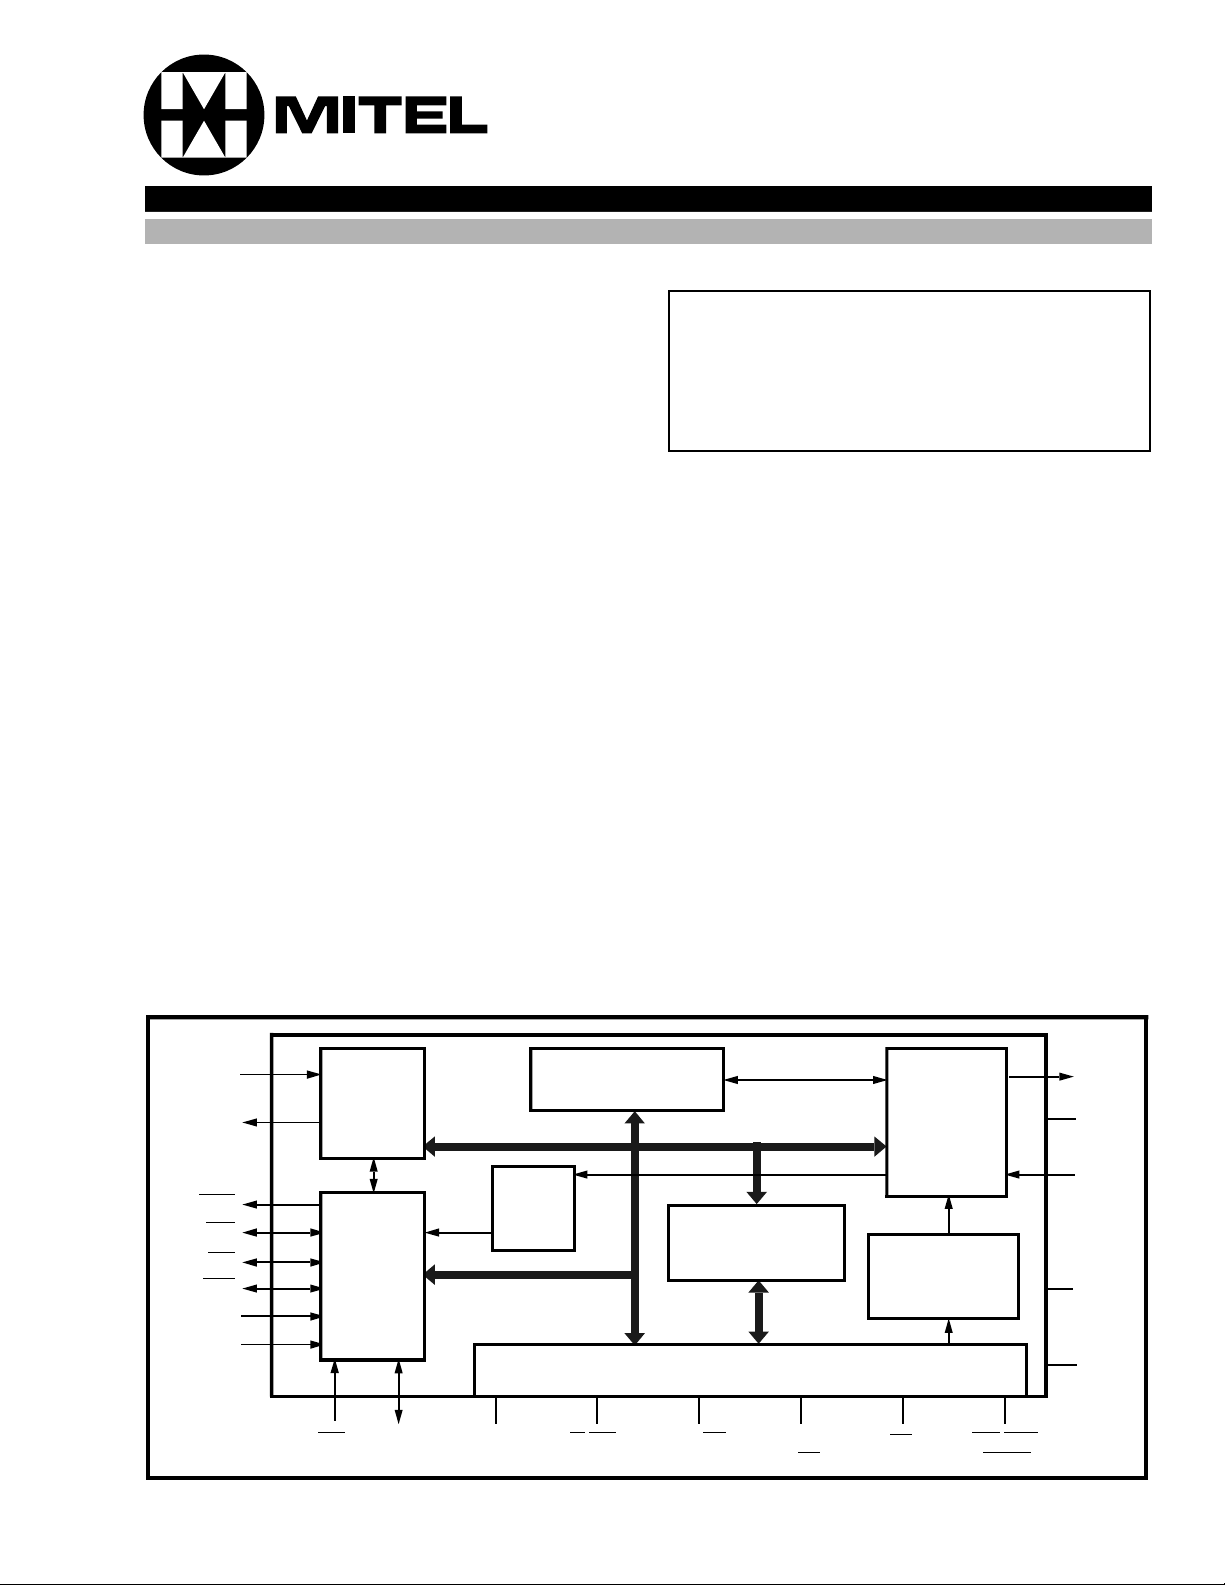
Figure 1 - Functional Bloc k Diagram
D-channel Priority
Mechanism
AFT/PRI
HDLC
Transceiver
Microprocessor Interface
DS/RD,
DinB
AS/ALE,
P/SC
CS,
DReq
S-Bus
Link
Interface
Link
Activation
Controller
IRQ
DCack
/NDA,
LTx
VBias
LRx
V
DD
V
SS
9-35
Page 2
MT8930C Preliminary Informatio n
LTx
AD1, IS1
AD2, SYNC/BA
NC
39
38
37
36
35
34
33
32
31
30
29
NC
LRx
40
NC
NC
STAR/Rsto
Rsti
NC
AD7, DR
AD6, AR
NC
AD5, M/S
AD4, MCH
AD3, MFR
NC
/WR, AFT/PRI
R/W
DS/RD
AS/ALE, P/SC
/NDA, DCack
IRQ
HALF
C4b
F0b
F0od
DSTi
DSTo
Cmode
CK/NT
, DinB
CS, DReq
VSS
1
2
3
4
5
6
7
8
9
10
11
12
13
14
28 PIN PDIP/CERDIP
28
27
26
25
24
23
22
21
20
19
18
17
16
15
VDD
VBias
LTx
LRx
STAR/Rsto
Rsti
AD7, DR
AD6, AR
AD5, M/S
AD4, MCH
AD3, MFR
AD2, SYNC/BA
AD1, IS1
AD0, IS0
R/W
/WR, AFT/PRI
DS/RD
F0od
DSTi
DSTo
NC
NC
NC
Cmode
CK/NT
NC
, DinB
NCNCC4b
F0b
HALF
VDD
VBias
NC
6 5 4 3 2 44434241
7
8
9
10
11
12
13
14
15
16
17
NC
AS/ALE, P/SC
1
231819 2021 22 2425 2627 28
VSS
CS, DReq
/NDA, DCack
IRQ
44 PIN PLCC
NC
AD0, IS0
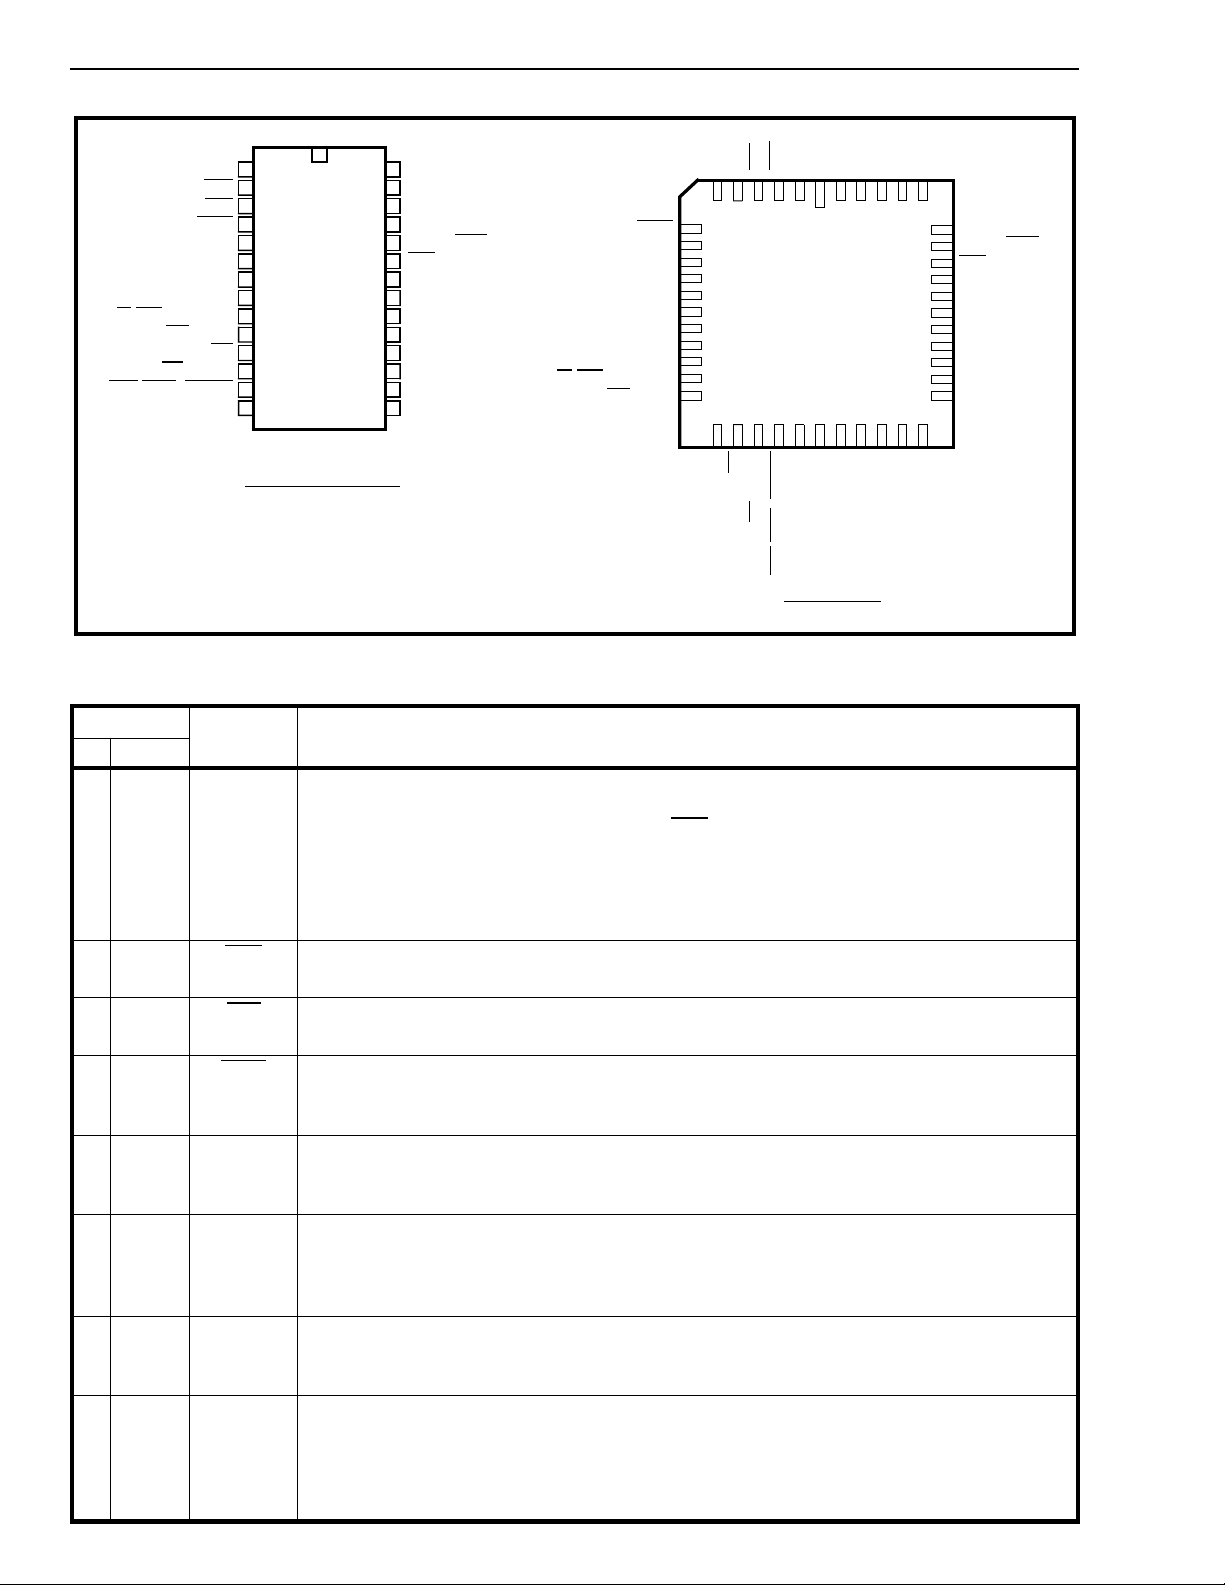
Figure 2 - Pin Connections
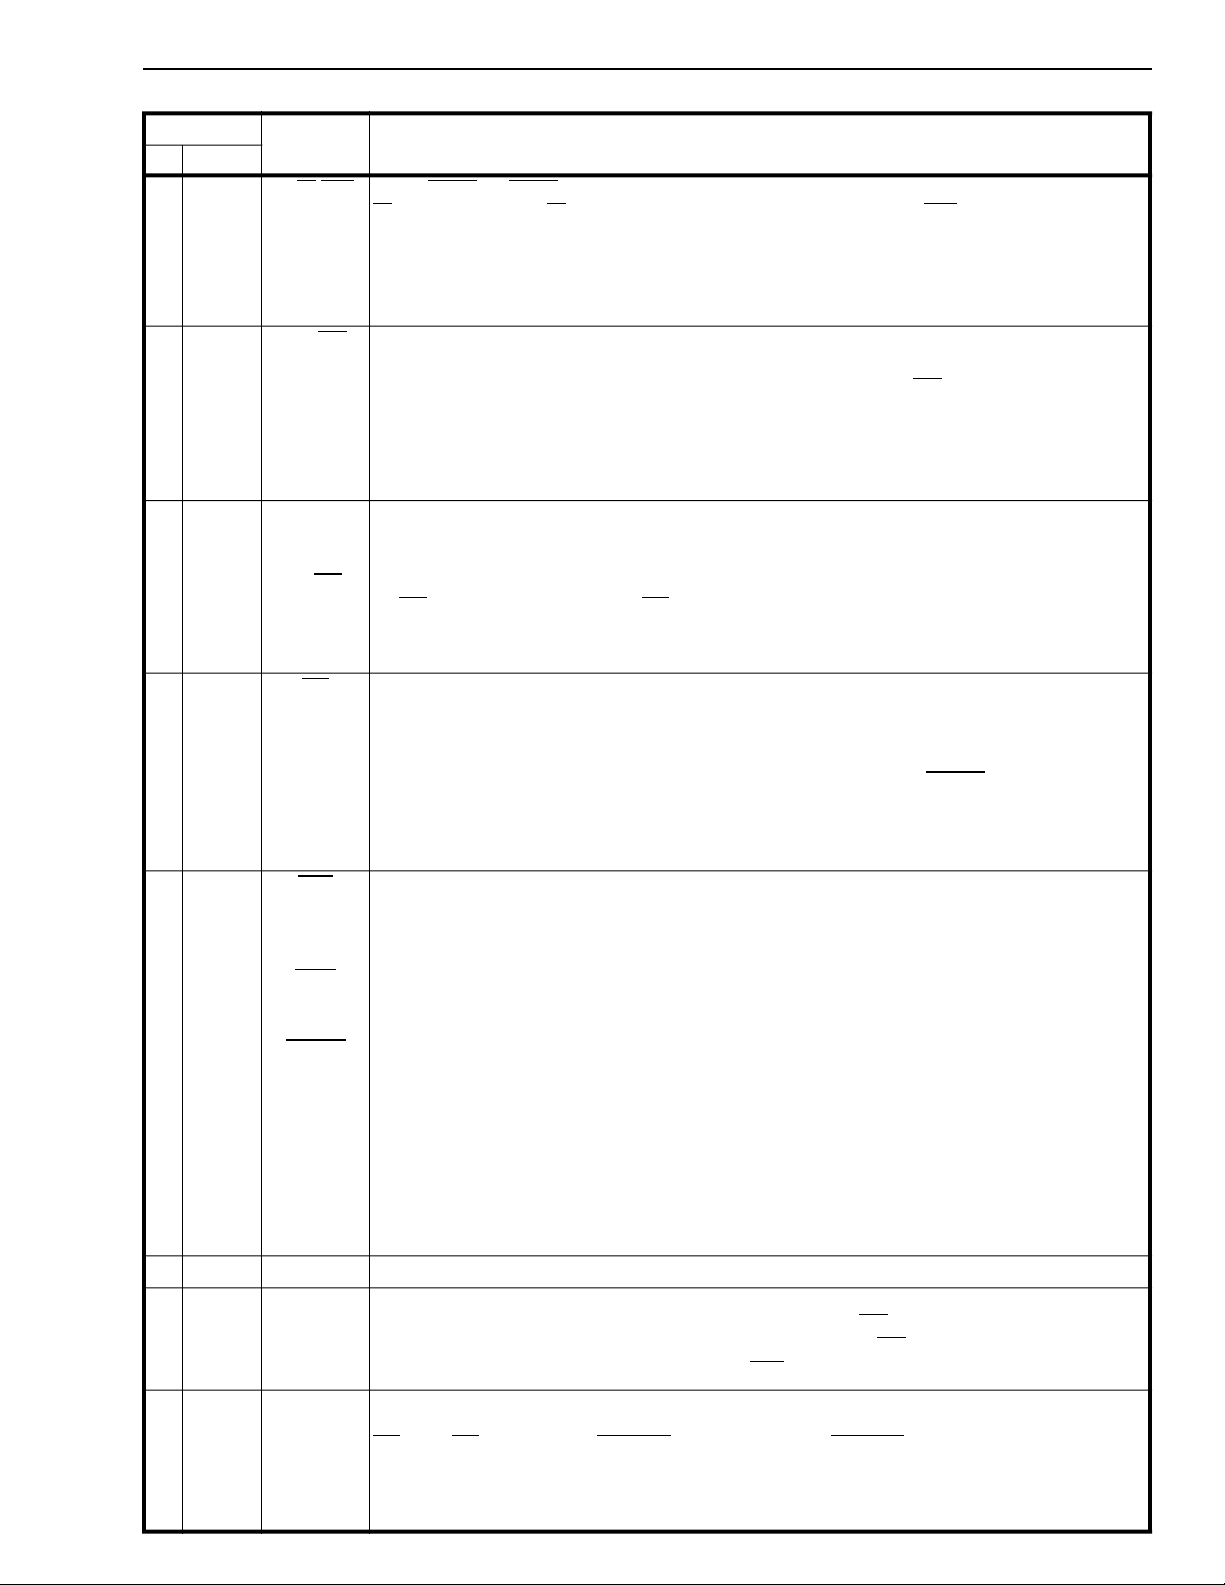
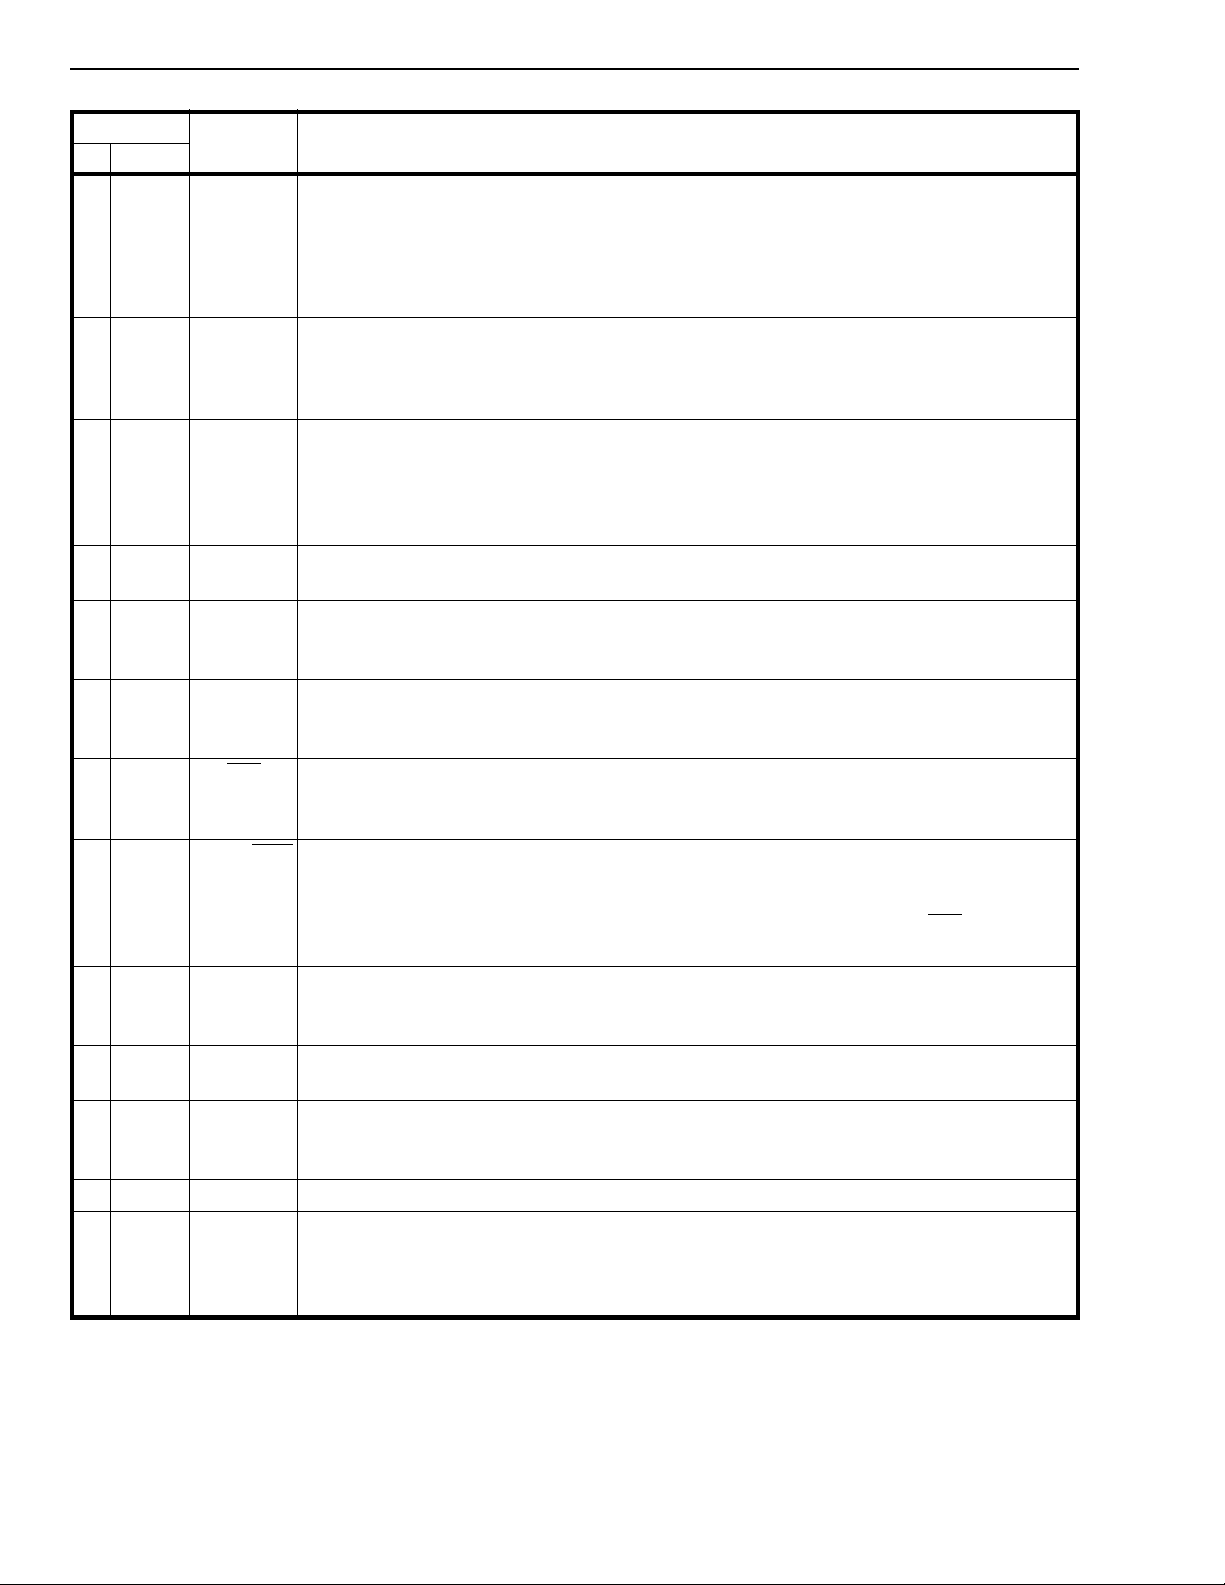
Pin Description
Pin #
DIP PLCC
12 HALFHALF Input/Output: this is an input in NT mode and an output in TE mode identifying
Name Description
which half of the S-interface frame is currently being written/read over the ST-BUS
(HALF = 0 sampled on the falling edge of C4b
within the frame pulse low window,
identifies the information to be transmitted/received in the first half of the S-Bus frame
while HALF = 1 identifies the information to be transmitted/received into the second half
of the S-Bus frame). Tying this pin to V
SS
or V
DD
free run. This signal can also be accessed from the ST-BUS C-channel.
in NT mode will allow the device to
2 3 C4b
4.096 MHz Clock: a 4.096 MHz ST-BUS Data Clock input in NT mode.
In TE mode, a 4.096 MHz output clock phase-locked to the line data signal.
34 F0b
Frame Pulse: an active low frame pulse input indicating the beginning of active STBUS channel times in NT mode. Frame pulse output in TE mode.
47 F0od
Delayed Frame Pulse Output: an active low delayed frame pulse output indicating
the end of active ST-BUS channels for this device. Can be used to daisy chain
to other ST-BUS devices to share an ST-BUS stream.
5 8 DSTi Data ST-BUS Input: a 2048 kbit/s serial PCM/data ST-BUS input with D, C, B1, and B2
channels assigned to the first four timeslots. These channels contain data to be
transmitted on the line and chip control information.
69 DSToData ST-BUS Output: a 2048 kbit/s serial PCM/data ST-BUS output with D, C, B1 and
B2 channels assigned to the first four timeslots respectively. The remaining timeslots
are placed into high impedance. These channels contain data received from the line
and chip status information.
713 CmodeController Mode Select Input: when high, microprocessor control is selected. When
low the controllerless mode is enabled and the microport pins are redefined as control
inputs and status outputs.
8 14 CK/NT TE Clock/Network Termination Mode Select Input. For TE mode, this pin must be
tied to V
applications). For NT mode, this pin must be tied to V
or to a 4.096 MHz clock (a clock is required for standard ISDN TE
SS
. Refer to “ST-BUS Interface”
DD
section for further explanation. A pull-up resistor is needed when driven by a TTL
device.
9-36
Page 3
Preliminary Information MT8930C
Pin Description (continued)
Pin #
DIP PLCC
916R/W/WR
10 17 DS/RD
11 19 AS/ALE
Name Description
or Write Input (Cmode = 1): defines the data bus transfer as a read (R/
AFT/PRI
Read/Write
=1) or a write (R/W=0) in Motorola bus mode. Redefined to WR in Intel bus mode.
W
Adaptive-Fixed Timing/Priority Select Input (Cmode=0): in NT mode, causes the
PLL and Rx filters and peak detectors to be disabled in favour of fixed timing and fixed
thresholds for short passive bus operation (0=fixed, 1=adaptive). In TE mode, this is the
Priority input. High priority (PRI=1) is normally reserved for signalling.
Data Strobe/Read Input (Cmode = 1): active high input indicates to the SNIC that
valid data is on the bus during a write operation or that the SNIC must output data
during a read operation in Motorola bus mode. Redefined to RD
DinB
D-Channel in B1 Timeslot Input (Cmode = 0): active high input that causes all
eight ST-BUS D-channel bits, instead of the usual two bits, to be routed to and
from the S-interface B1 timeslot. When active, marks are transmitted in the
S-interface D-channel.
Address Strobe/Address Latch Enable Input (Cmode = 1): in Motorola bus mode
the falling edge is used to strobe the address into the SNIC during microprocessor
access. Redefined to ALE in Intel bus mode.
P/SC
Parallel/Serial Control Input (Cmode = 0): determines if the serial C-channel
=0) or microport pins (P/SC=1) are the source of chip control when controllerless
(P/SC
mode is selected. If the ST-BUS is chosen as the source, the dedicated Control input
pins are ignored but the status output pins remain valid.
in Intel bus mode.
12 20 CS
DReq
IC
13 21 IRQ
NDA
DCack
IC
14 22 V
15-2224-26
AD0-7 Bidirectional Address/Data Bus (Cmode = 1): electrically and logically compatible to
30-32
34-35
15-1624-
IS0-IS1 Internal State Outputs (Cmode =0): Binary encoded state number outputs.
25
SS
Chip Select Input (Cmode=1): active low input used to select the SNIC for
microprocessor access.
D-Channel Request Input (Cmode = 0): an active high input that in TE mode only
causes the SNIC to transmit a “01111110” flag immediately if the D-channel is free, or
wait until it becomes available and then transmit the flag. The DCack
signals the
successful acquisition of the D-channel. If DReq is tied low, continuous ones are
transmitted in the S-Bus D-channel.
Internal Connection (Cmode = 0): tie to V
for normal operation in NT mode only.
SS
Interrupt Request (Open Drain Output) (Cmode = 1): an output indicating an
unmasked HDLC interrupt. The interrupt remains active until the microprocessor clears
it by reading the HDLC Interrupt Status Register. This interrupt source is enabled with
B2=0 of Master Control Register.
New Data Available (Open Drain Output) (Cmode = 1): an active low output signal
indicating availability of new data from the S-Bus. This signal is selected with B2=1 of
Master Control Register.
D-Channel Acknowledge (Open Drain Output) (Cmode = 0): in TE mode only
indicates that the SNIC has gained access to the D-channel in response to a DReq and
has transmitted the first zero of an opening flag. The user should immediately begin
transmitting the rest of the packet over the ST-BUS D-channel. If this signal goes high
in the middle of transmission, the TE has lost the bus and must regain access of the Dchannel before retransmitting the packet.
Internal Connection (Open Drain Output) (C-mode=0). This pin is not used in NT
mode and should be left disconnected.
This pin must be tied to V
with a 10kΩ resistor.
DD
Ground.
either Intel or Motorola micro-bus specifications. If DS/RD
AS/ALE then the chip operates to Motorola specs. If DS/RD
of AS/ALE Intel mode is selected. Taking Rsti
IS0 IS1 NT Mode TE Mode
0 0 deactivated deactivated
0 1 pending deactivation synchronized
1 0 pending activation activation request
1 1 activated activated
low sets Motorola mode.
is low on the rising edge of
is high on the rising edge
9-37
Page 4
MT8930C Preliminary Informatio n
Pin Description (continued)
Pin #
DIP PLCC
17 2 6 SYNC/B A Synchronization/Bus Activity Output (Cmode = 0): output indicating synchronization
18 30 MFR Multiframe Input/Output (Cmode=0): multi frame input in NT mode or output in TE
19 31 MCH Maintenance Channel (Q-channel) Input/Output (Cmode=0): an output in NT mode
20 32 M/S M/S Input/Output (Cmode=0): M/S bit input in NT mode or M/S bit output in TE mode.
21 34 AR Activate Request Input (Cmode = 0): asserting AR with DR = 0 will initiate the
22 35 DR Deactivate Request Input (Cmode = 0): asserting DR high will initiate the appropriate
Name Description
to incoming RX frames when activation request is asserted and the deactivation request
is ’0’ (AR = 1 and DR = 0). Synchronization is declared once three successive frames
conforming to the 14-bit bipolar violation criteria have been detected. If part is
deactivated or activation request is ’0’ (AR = 0 or DR = 1), this pin indicates the
presence of bus activity.
mode. Setting this pin to one in NT mode when HALF = 1, forces the F
respectively. This pin going high in TE mode indicates that F
received. This signal is updated on the rising edge of the HALF signal.
which is valid only in the frame following the transmission of MFR. In TE mode, this is
the maintenance channel (Q-channel) input which is transmitted in the F
following the reception of the multiframe signal. This input is sampled on the falling
edge of the HALF signal.
M is read or written when HALF=1 while S is read or written when HALF=0.
appropriate S-interface activation sequence coded in the NT or TE activation/
deactivation controller.
S-interface deactivation sequence coded in the NT or TE activation/ deactivation
controller.
, N pair to 1, 0
= 1 & N= 0 has been
A
A
and L bits
A
23 37 Rsti
Reset Input: Schmitt trigger reset input. If ’0’, sets all control registers to the default
conditions, resets activation state machines to the deactivated state, resets HDLC,
clears the HDLC FIFO‘s. Sets the microport to Motorola bus mode.
24 38 STAR/Rsto
Star/Reset (Open Drain Output): 192kbit/s Rx data output fixed relative to the STBUS timebase. A group of NTs, in fixed timing mode, can be wire or’ed together to
create a Star configuration. Active low reset output in TE mode indicating 128
consecutive marks have been received. Can be connected directly to Rsti
to reset all TEs on the bus. This pin must be tied to V
with a 10 kΩ resistor.
DD
to allow NT
25 40 LRx Receive Line Signal Input: this is a high impedance input for the pseudoternary line
signal to be connected to the line through a 2:1 ratio transformer. See Figures 20 and
21. A DC bias level on this input equal to V
must be maintained.
Bias
26 42 LTx Transmit Line Signal Output: this is a current source output designed to drive a
nominal 50 ohm line through a 2:1 ratio transformer. See Figures 20 and 21.
27 43 V
Bias
Bias Voltage: analog ground for Tx and Rx transformers. This pin must be decoupled
through a 10µF capacitor with good high frequency characteristics (i.e.,
to V
DD
tantalum).
28 44 V
1,5-6,1012,15,18,
23,27-
29, 33,
36, 39, 41
DD
NC No Connection.
Power Supply Input.
9-38
Page 5
Preliminary Information MT8930C
Functional Description
The MT8930C Subscriber Network Interface Circuit
(SNIC) is a multifunction transceiver providing a
complete interface to the S/T Reference Point as
specified in ETS 300-012, CCITT Recommendation
I.430 and ANSI T1.605. Implementing both
point-to-point and point-to-multipoint voice/data
transmission, the SNIC may be used at either end of
the digital subscriber loop. A pro grammable digital
interface allows the MT8930C to be configured as a
Network Termination (NT) or as a Terminal
Equipment (TE) device.
The SNIC supports 192 kbit/s (2B+D + overhead) full
duplex data transmission on a 4-wire balanced
transmission line. Transmission capability for both B
and D channels, as well as related timing and
synchronization functions, are provided on chip. The
signalling capability and procedures necessary to
enable customer terminals (TEs) to be activated and
deactivated, form part of the MT8930C’s
functionality. The SNIC handles D-channel resource
allocation and prioritization for access contention
resolution and signa llin g re qui rem ents in pa ssive bus
line configurations. Control and status information
allows implementation of maintenance functions and
monitoring of the device and the subscriber loop.
An HDLC transc ei ve r is i n c lude d on th e S NI C for link
access protocol handling via the D-channel.
Depacketized data is passed to and from the
transceiver via the micropro cessor port. Two 19 byte
deep FIFOs, one for transmit and one for receive,
are provided to bu ffer the da ta . The HD L C bl ock can
be set up to transmit or receive to/from either the
S-interface port or the ST-BUS port. Further, the
transmit destination and receive source can be
independe ntly selected, e.g., tran smit to S-interface
while receiving from ST-BUS. The transmit and
receive paths can be separately enabled or disabled.
Both, one and two byte address recognition is
supported by the SNIC. A transparent mode allows
data to be passe d directly to the D channel without
being packet ize d.
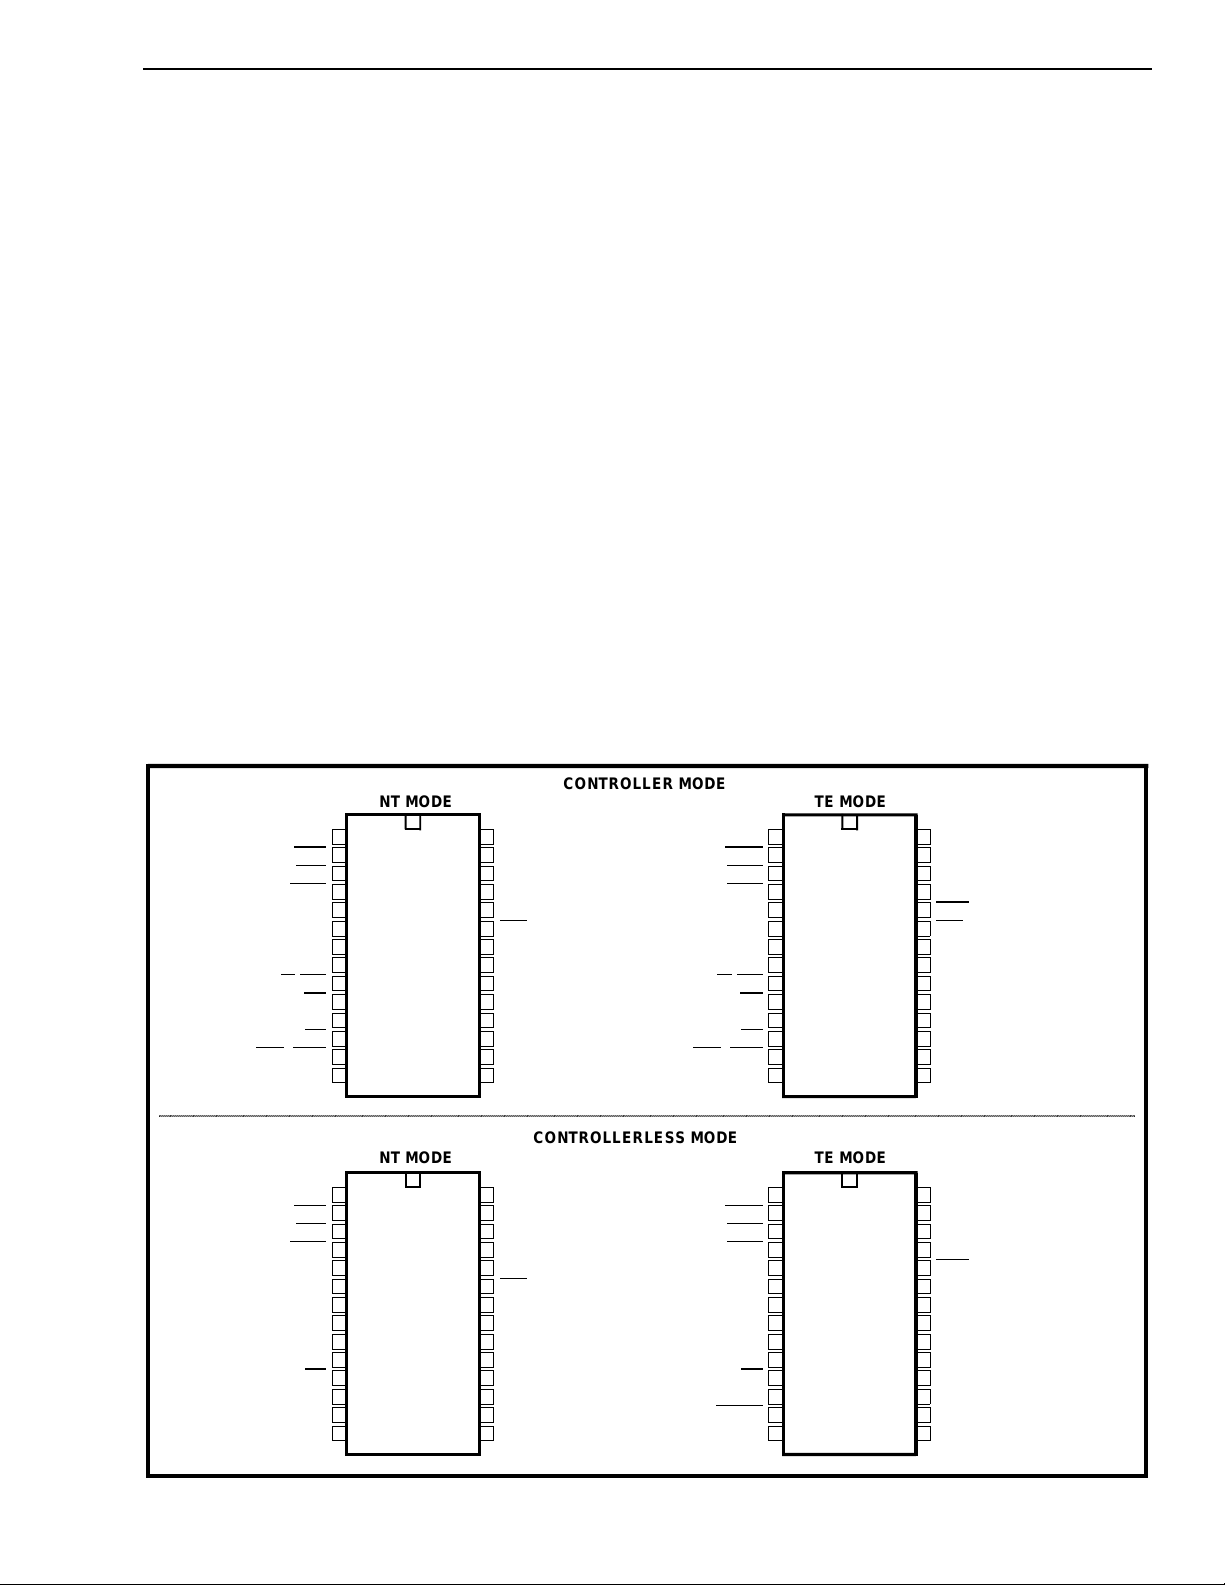
A block diagram of the MT8930C is shown in Figure
1. The SNIC has three interface ports: a 4-wire
CCITT compatible S/T interface (subscriber loop
interface), a 2048 kbit/s ST-BUS serial port, and a
general purpose parallel microprocessor port. This
8-bit para lle l por t is comp ati ble with bot h Mo tor ola or
HALF
C4bi
F0bi
F0od
DSTi
DSTo
Cmode
NT
/WR
R/W
DS/RD
AS/ALE
CS
IRQ, NDA
VSS
HALF
C4bi
F0bi
F0od
DSTi
DSTo
Cmode
NT
AFT
DinB
P/SC
VSS
NT MODE
1
2
3
4
5
6
7
8
9
10
11
12
13
14
NT MODE
1
2
3
4
5
6
7
8
9
10
11
IC
12
IC
13
14
28
27
26
25
24
23
22
21
20
19
18
17
16
15
28
27
26
25
24
23
22
21
20
19
18
17
16
15
VDD
VBias
LTx
LRx
STAR
Rsti
AD7
AD6
AD5
AD4
AD3
AD2
AD1
AD0
VDD
VBias
LTx
LRx
STAR
Rsti
DR
AR
M/Si
MCHo
MFRi
SYNC/BA
IS1
IS0
CONTROLLER MODE
HALF
DSTo
Cmode
R/W
DS/RD
AS/ALE
IRQ, NDA
CONTROLLERLESS MODE
HALF
DSTo
Cmode
DReq
DCack
C4bo
F0bo
F0od
DSTi
CK
/WR
CS
VSS
C4bo
F0bo
F0od
DSTi
CK
PRI
DinB
P/SC
VSS
TE MODE
1
2
3
4
5
6
7
8
9
10
11
12
13
14
TE MODE
1
2
3
4
5
6
7
8
9
10
11
12
13
14
28
27
26
25
24
23
22
21
20
19
18
17
16
15
28
27
26
25
24
23
22
21
20
19
18
17
16
15
VDD
VBias
LTx
LRx
Rsto
Rsti
AD7
AD6
AD5
AD4
AD3
AD2
AD1
AD0
VDD
VBias
LTx
LRx
Rsto
Rsti
DR
AR
M/So
MCHi
MFRo
SYNC/BA
IS1
IS0
Figure 3 - SNIC Pin Connections in Various Modes
9-39
Page 6
MT8930C Preliminary Informatio n
AAAA
A
A
A
A
A
AAAA
A
A
A
A
A
A
AAAA
A
A
A
A
A
A
AAAA
AAA
AAAA
AAA
AAAA
AAA
AAAA
AAA
AAAA
AAA
AAAA
AAA
SNIC also has provisions for a controllerless mode
(Cmode=0), where the microprocessor port is
redefined to allow access to the control/status
registers via external hardware.
The three major blocks of the MT8930C, consisting
of the system serial interface (ST-BUS), HDLC
transceiver, and the digital subscriber loop interface
(S-interface) are interconnected by high speed data
busses. Data sent to and received from the
S-interface port (B1, B2 and D channels) can be
accessed from either the parallel microprocessor
port or the serial ST-BUS port. This is also true for
SNIC control and status information (C-channel).
Depacketized D-channel information to and from the
HDLC section can only be accessed through the
parallel microprocessor port.
S-Bus Interface
AAA
AAAA
AAA
AAAA
AAA
AAAA
AAA
AAAA
AAA
AAAA
AAA
Intel microprocessor bus signals and timing. The
B1 B1 B1 B1 B1 B1 B1 B1 B2 B2 B2 B2 B2 B2 B2 B2
AAAA
B1 B1 B1 B1 B1 B1 B1 B1 B2 B2 B2 B2 B2 B2 B2 B2
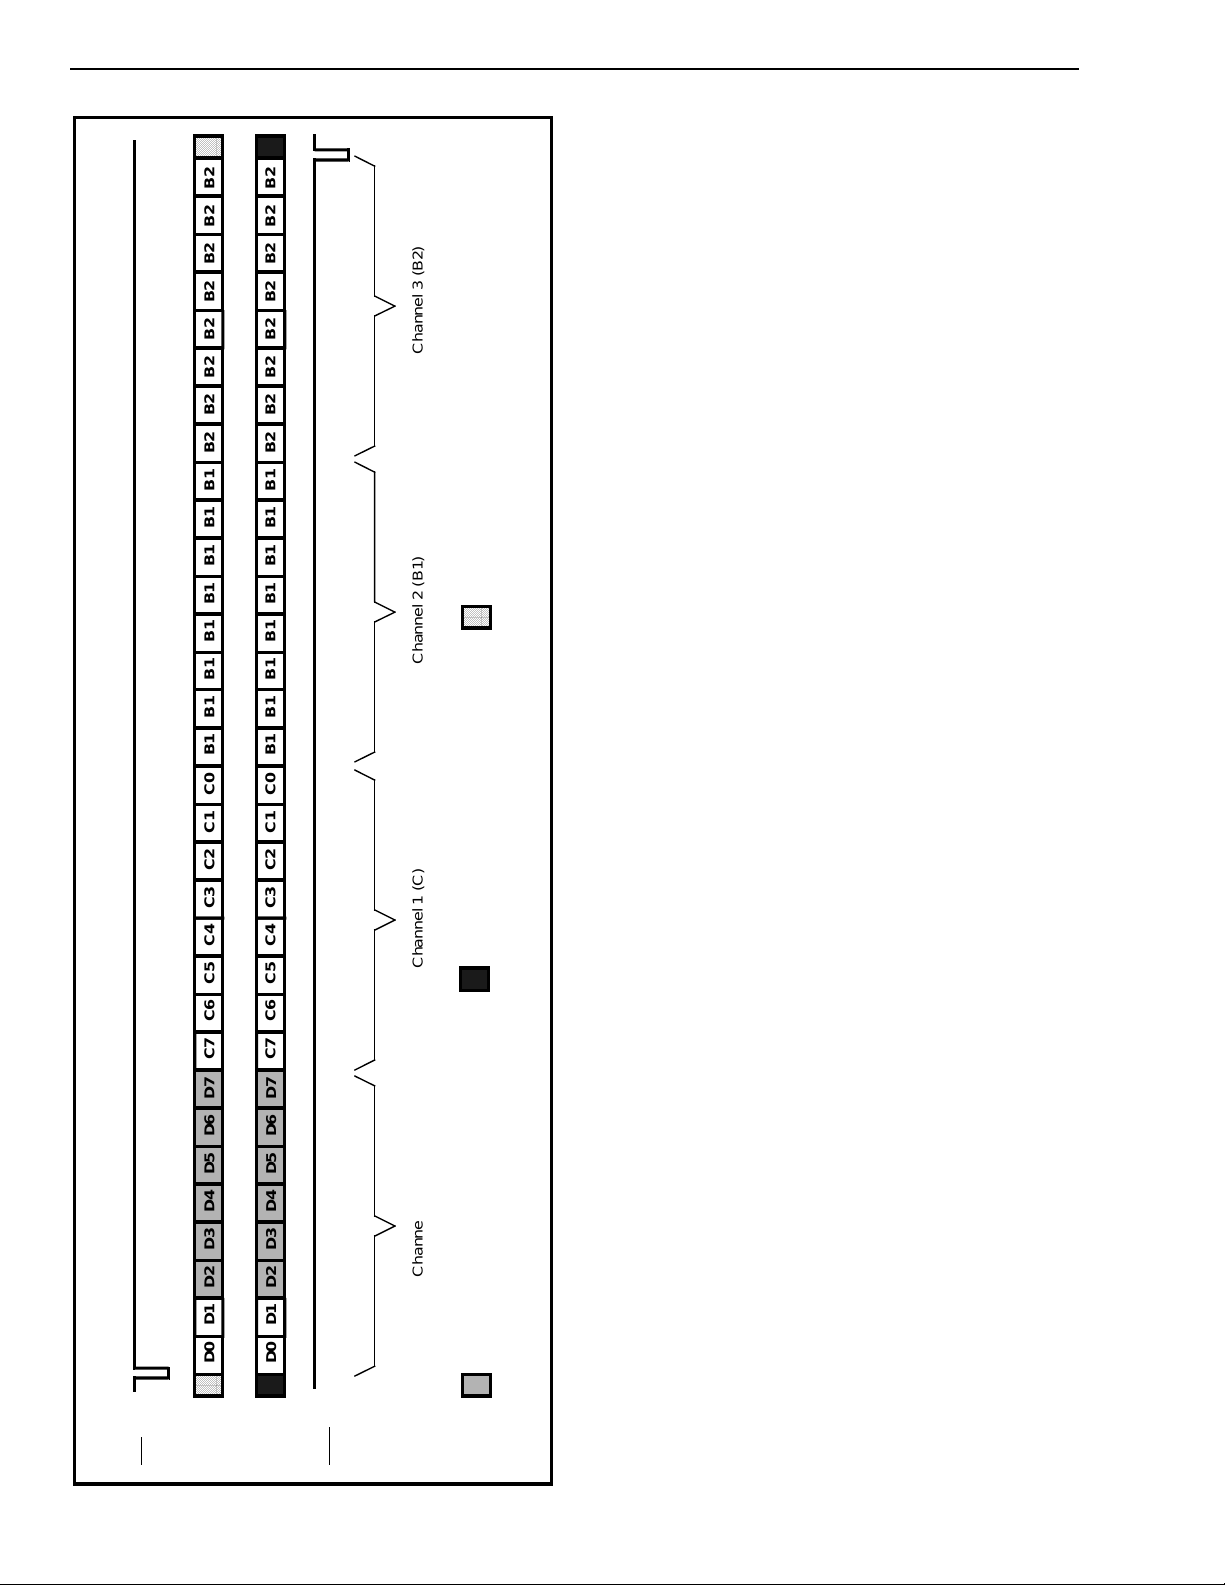
The S-Bus is a four wire, full duplex, time division
multiplexed transmission facility which exchanges
information at 192 kbit/s rate inc luding two 64 kbit/s
PCM voice or data channels, a 16 kbit/s signalling
channel and 48 kbit/s for synchronization and
overhead. The relative position of these channels
with respect to the ST-BUS is shown in Figures 4
and 5.
Channel 1 (C) Channel 2 (B1) Channel 3 (B2)Channel 0 (D)
F0b
C7 C6 C5 C4 C3 C2 C1 C0
D0 D1 D2 D3 D4 D5 D6 D7
AAAA
AAA
AAAA
AAA
AAAA
AAA
AAAA
AAA
AAAA
AAA
AAAA
AAA
DSTi
C7 C6 C5 C4 C3 C2 C1 C0
D0 D1 D2 D3 D4 D5 D6 D7
DSTo
Only valid with 64 kbit/s D-channel Output in high impedance state Don’t care
F0od
Figure 4 - ST-BUS Channel Assignment
The SNIC makes use of the first four channels on the
ST-BUS to transmit and receive control/status and
data to and from the S-interface port. These are the
B, D and C-channels (see Figure 4).
The B1 and B2 channels each have a bandwidth of
64 kbit/s and are used to carry PCM voice or data
across the network .
The D-channel is primarily intended to carry
signalling information for circuit switching through
the ISDN network. The SNIC provides the capability
of having a 16 kbit/s or full 64 kbit/s D-channel by
allocating the B1-channel timeslot to the D-channel.
Access to the depacketized D-channel is only
granted throug h the pa ral lel mi crop roce ss or por t.
The C-channel provides a means for the system to
control and monitor the functionality of the SNIC.
This control/status channel is accessed by the
system through the ST-BUS or microprocessor
port. The C-channel provides access to two
registers which provide complete control over the
state activation machine, the D-channel priority
mechanism as well as the various maintenance
functions. A detaile d de scri p tion of the s e regi ste rs i s
discussed in the microprocessor port interface.
9-40
Page 7
Preliminary Information MT8930C
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
A
A
A
A
A
A
A
A
A
A
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
A
A
A
A
A
A
A
A
A
A
A
A
AAAA
AAAA
A
A
A
A
AA
AAAA
A
A
A
A
AA
AAAA
A
A
A
A
AA
AAAA
AAAA
AAAA
A
A
A
A
A
A
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
B1 B1B1
62.5 µs
Note: Shaded areas reveal data mapping
B1
AAAA
AAA
AAAA
AAA
AAAA
AAA
AAAA
AAA
AAAA
AAA
AAAA
AAAA
AAAA
AAAA
AAAA
B2 L LD1 B1B1 B1B1 B1 B1 B1 L D0 L B2 B2 B2 B2B1 B2 B2 B2 B2 L D1 LB2 L LD1 LFB1B1 B1 B1 B1 B1 B1 L D0 L Fa LB1 B2 B2 B2 B2 B2 B2 B2 FL
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
AAAA
B1 B1 B1B1 B1B1 EB1 D0 B2 B2 B2 B2 B2 B2 B2 B2 ES D1 L F L B1 B1FL B1B1 B1B1 B1B1 B1 E D0 A Fa NB2B2B2B2B1 B2 B2 B2 B2 E D1 M B1 B1 B1
62.5 µs
62.5 µs
A = Activation bit
M = Multiframing bit
S = S-channel bit
B1 = Bit within B1-channel
B2 = Bit within B2-channel
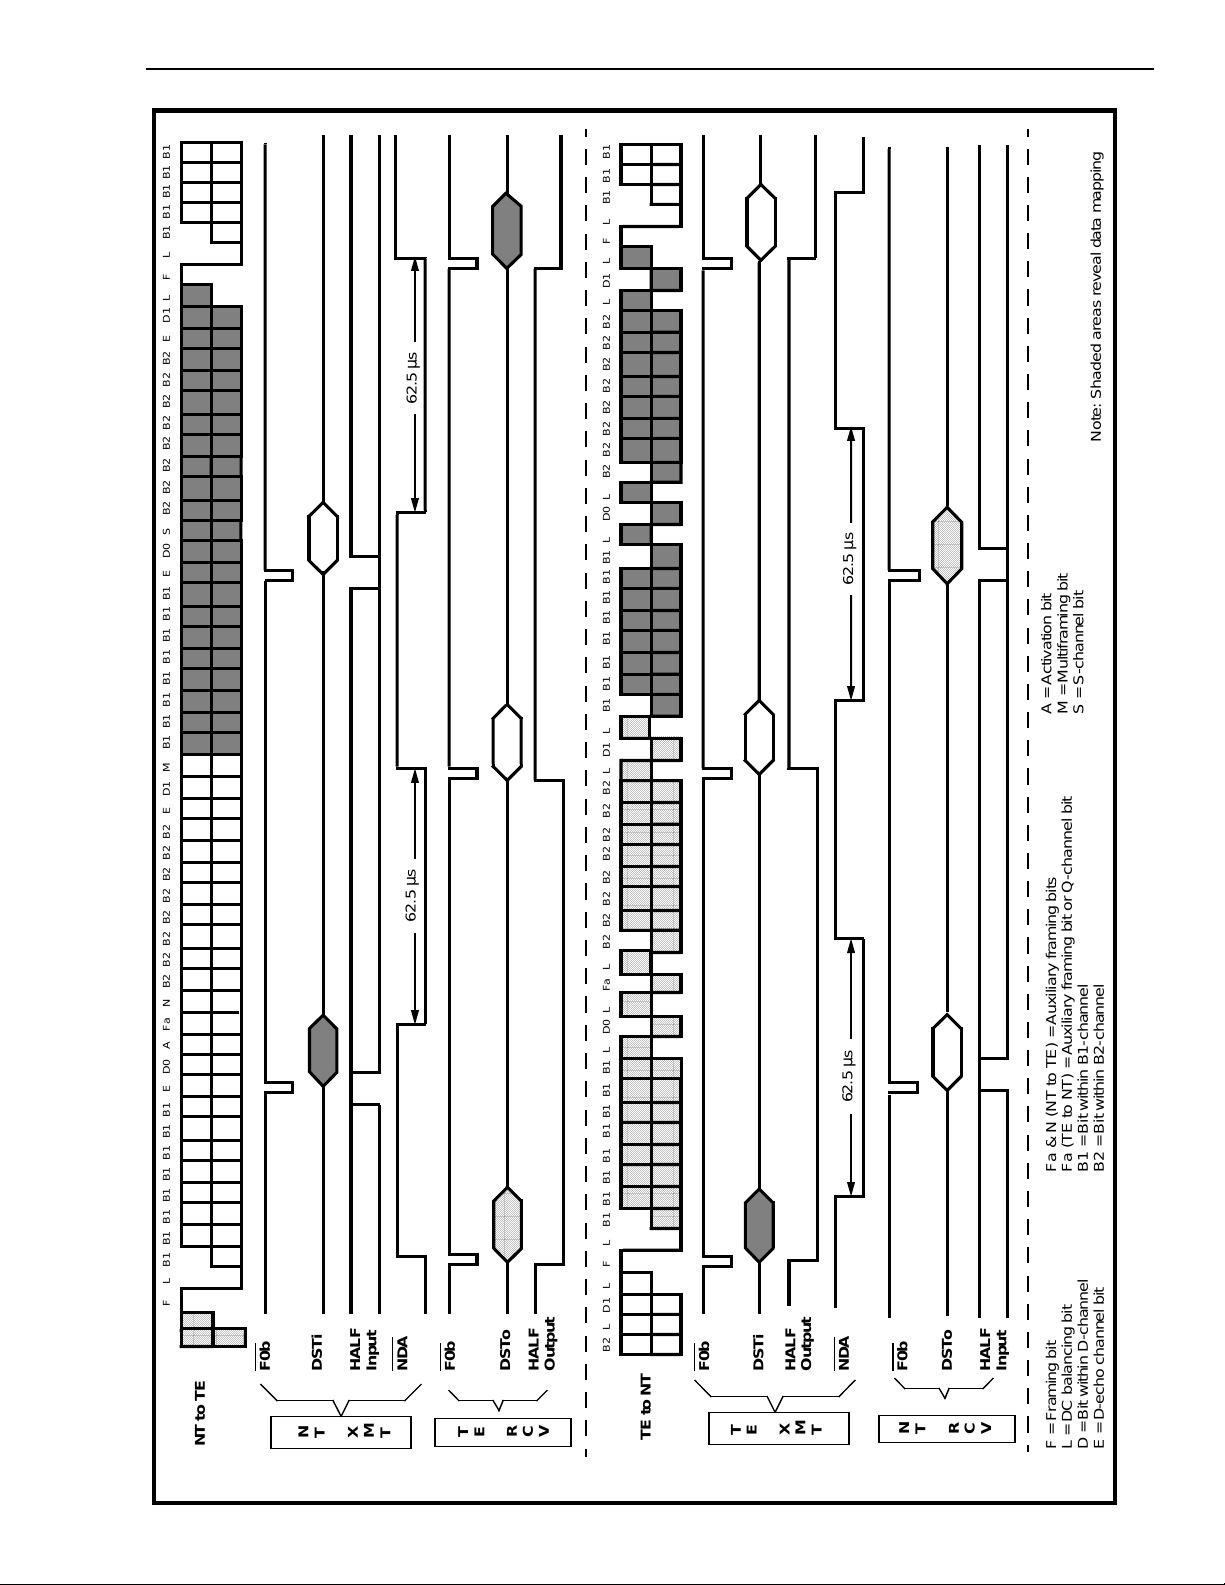
Figure 5 - S-Bus Frame Structure and Functional Timing
62.5 µs
Fa & N (NT to TE) = Auxiliary framing bits
Fa (TE to NT) = Auxiliary framing bit or Q-channel bit
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
AAA
AAAA
A
F0b
DSTi
TEX
HALF
Output
M
T
NDA
F0b
NTR
DSTo
HALF
Input
V
C
F = Framing bit
L = DC balancing bit
D = Bit within D-channel
E = D-echo channel bit
9-41
F0b
NT to TE
NTX
Input
DSTi
HALF
NDA
F0b
DSTo
HALF
Output
T
M
TER
C
V
TE to NT
Page 8
MT8930C Preliminary Informatio n
Line Code
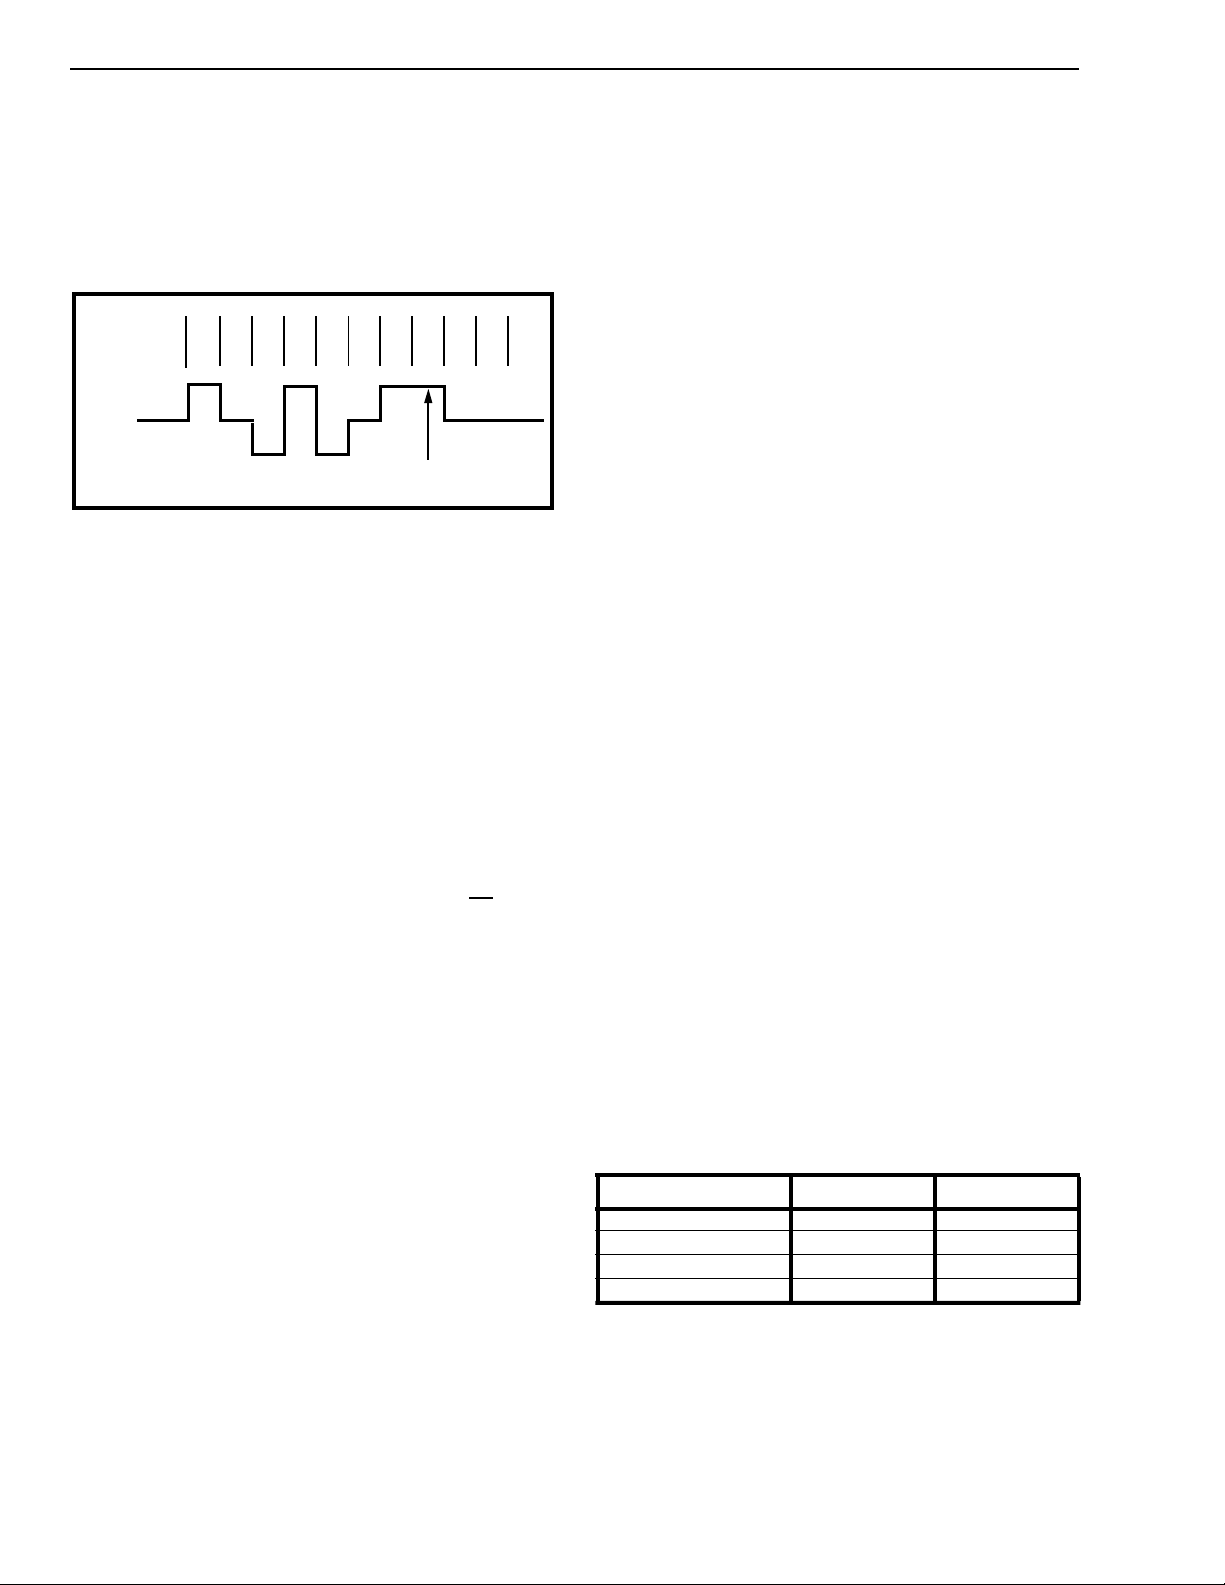
The line code used on the S-interface is a Pseudo
ternary code with 100% pulse width as seen in
Figure 6 below. Binary zeros are represented as
marks on the line and successive marks will
alternate in polarity.
BINARY
VALUE
LINE
SIGNAL
0100010011
Violation
Figure 6 - Alternate Zero Inversion Line Code
A mark which does not adhere to the alternating
polarity is kno wn as a bip olar viol atio n.
Framing
The valid frame structure transmitted by the NT and
TE contains the following (refer Fig. 5):
NT to TE:
- Framing bit (F)
- B1 and B2 channels (B1,B2)
- DC balancing bits (L)
- D-channel bits (D0, D1)
- Auxiliary framing and N bit (Fa, N), N=Fa
- Activation bit (A)
- D-echo channel bits (E)
- Multiframing bit (M)
- S-channel bit
TE to NT:
- Framing bit (F)
- B1 and B2 channels (B1, B2)
- DC balancing bits (L)
- D-channel bits (D0, D1)
- Auxiliary framing bit (Fa) or Q-channel bit
The framing mechanism on the S-interface makes
use of line code violations to identify frame
boundaries. The F-bit violates the alternating
line code sequence to allow for quick identification of
the frame boundaries. To secure the frame
alignment, the next mark following the frame
balancing bit (L) will also produce a line code
violation. If the data following the balancing bit is all
binary ones, the zero in the auxiliary framing bit (Fa)
or N-bit (for the direction NT to TE) will provide
successive violations to ensure that the 14 bit
criterion (13 bit criterion in the direction TE to NT)
specified in Recommendations I.430 and T1.605 is
satisfied. If the B1-channel is not all binary ones, the
first zero followin g the L-bit will violate th e line code
sequence, thus allowing subsequent marks to
alternate without bipolar violations.
The Fa and N bits can also be used to identify a
multiframe structure (when this is done, the 14 bit
criterion may not be met). This multiframe structure
will make provisions for a low speed signalling
channel to be used in the TE to NT direction
(Q-channel). It will consist of a five frame multiframe
which can be identified by the binary inversion of the
Fa and N-bit on the first frame and consequently on
every fifth f rame of the multifra me. Upon detection
of the multiframe signal, the TE will replace the next
Fa-bit to be transmitted with the Q-bit.
The DC balancing bits (L) are used to remove any
DC content from the line. The balancing bit will be a
mark if the number of preceding marks up to the
previous balancing bit is odd. If the number of
marks is even, the L-bit will be a space.
The A-bit is used by the NT during line activation
procedures ( refer to stat e activa tion di agrams). The
state of the A-bit will advise the TE if the NT has
achieved syn c hr o ni zation.
The E-bit is the D-echo channel. The NT will reflect
the binary value of the received D-channel into the
E-bits. This is used to establish the access
contention resolution in a point-to-multipoint
configuration. This is described in more detail in the
section of th e D- c h an ne l p rio r i ty m e chanism.
The M-bit is a second level of multiframing which is
used for structuring the Q-bits. The frame with Mbit=1 identifies frame #1 in the twenty frame
multiframe. The Q-channel is then received as
shown in Table 1. All synchronization with the
multiframes must be performed externally.
FRAME # Q-Bit M-Bit
1Q11
6Q20
11 Q3 0
16 Q4 0
Table 1. Q-channel Allocation
Bit Order
When using the B-channels for PCM v oice, the first
bit to be transmitted on the S-Bus should be the sign
bit. This complies with the existing telecom
standards which transmit PCM voice as most
significant bit first. However, if the B-channels are to
9-42
Page 9
Preliminary Information MT8930C
carry data, the bit ordering must be reversed to
comply with the existing datacom standards (i.e.,
least signifi c an t bit fi rs t).
These contradicting standards place a restriction on
all information input and output through the serial
and parallel ports. Information transferred through
the serial ports, will maintain the integrity of the bit
order. Data sent to either serial port from the parallel
port, will transmit the least significant bit first.
Therefore, a PCM byte input through the
microprocessor port must be reordered to have the
sign bit as th e le a st s i gn i fic an t bi t.
When the microprocessor reads D, B1 or B2 channel
data of eithe r ST-BUS or S-bus seria l port, the le ast
significant bit read is the first bit received on that
particular c h an ne l of either seri al p ort.
The D-channel received on the serial ST-BUS ports
must be ordered with the least significant bit first as
shown in Figure 4. This also applies to the
D-channel directed to the ST-BUS from the
microproces sor po rt.
The C-channel bit mapping from the parallel port to
the ST-BUS is organized such that the most
significant bit is transmitted or received first.
State Activation
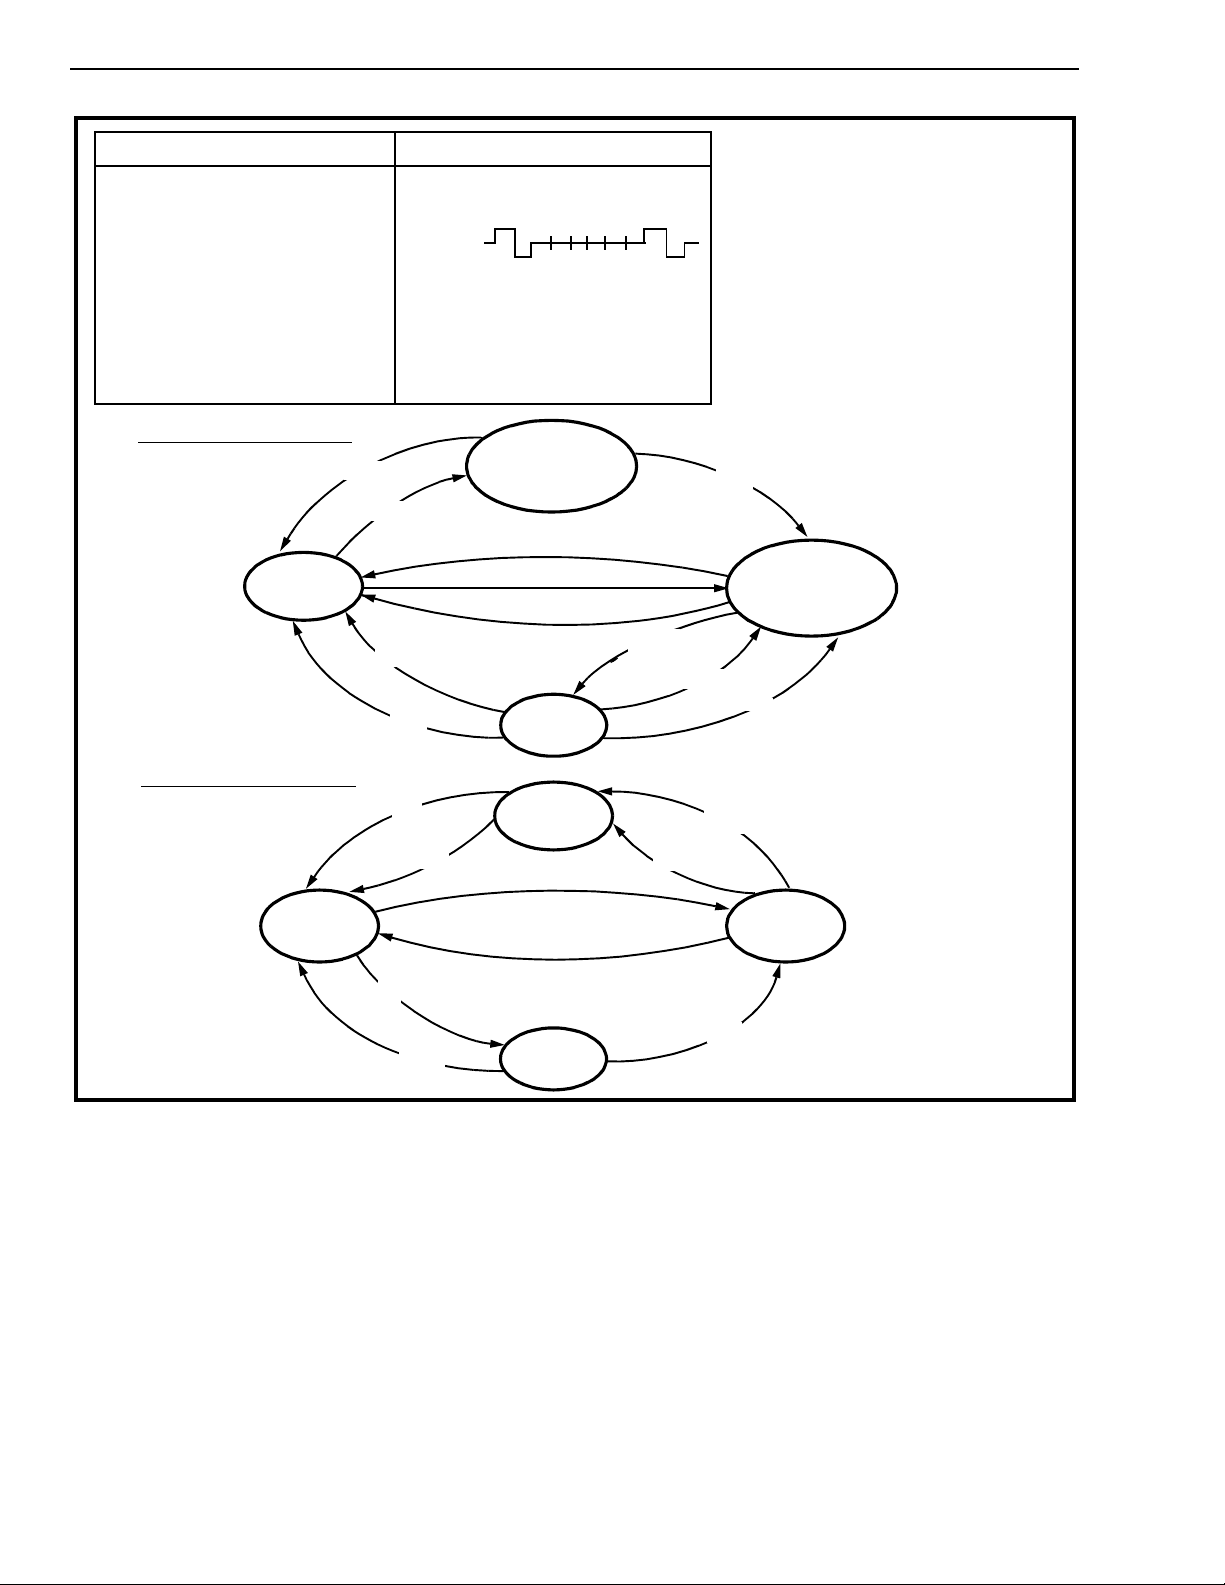
The state activation controller activates or
deactivates the SNIC in response to line activity or
external command. The controller is completely
hardware driven and need not be initialized by the
microprocessor. The state diagram for initialization
is shown in Figure 7.
The protocol used b y the state activati on co nt r oll er i s
defined as follows:
1) In the deactivated state, neither the NT nor
TE assert a signal on the line (Info0).
2) If the TE wants to initiate activation, it m ust
begin transmitting a continuous signal
consisting o f a po siti ve ze ro, a n ega tiv e ze ro
followed by six ones (Info1).
3) Once the NT has detected Info1, it begins to
transmit Info2 which consists of an S-Bus
frame with zeros in the B and D-channel and
the activation bi t (A -bit) s et to z e ro.
4) As soon as the TE synchronizes to Info2, it
responds with a valid S-Bus frame with data
in the B1, B2 and D-ch anne l (Info 3).
5) The NT will then transmit a valid frame with
data in the B1, B2 and D-channel. It will also
set the activation bit (A) to binary one once
synchronizatio n to Info 3 is ach ieve d.
If the NT wishes to ini ti a te the acti v at ion , st ep s 2 an d
3 are ignored and the NT starts sending Info2. To
initiate a deactivation, either end begins to send
Info0 (Idle line).
D-channel Priority Mechanism
The SNIC contains a hardware priority mechanism
for D-channel contention resolution. All TEs
connected in a point-to-multipoint configuration are
allocated the D-channel using a systematic
approach. Allocation of the D-channel is
accomplished by monitoring the D-echo channel
(E-bit) and incrementing the D-channel priority
counter with every consecutive on e echoed back in
the E bit. Any zero found on the D-echo channel will
reset the prio rity co un te r.
There are two classes of priority within the SNIC,
one user accessible and the other being strictly
internal. The user accessible priority selects the
class of operation and has precedence over the
internal priority. The latter (internal priority), will
select the level of priority within each class (i.e., the
internal priority is a subsection of the user accessi ble
priority). User accessible priorit y se lects th e t ermi nal
count as 8/9 or 10/11 consecutive ones on the E-bit
(8 being high priority while 10 being low priority).
The internal priority selects the terminal between 8
or 9 for high class and 10 or 11 for low class. The
first terminal equipment to attain the E-bit priority
count will immediately take control of the D-channel
by sending the opening flag. If more than one
terminal has the same prio r it y, all but one of them will
eventually detect a collision. The TEs that detect a
collision will immediately stop trans-mitting on the Dchannel, ge nerate an int errupt throug h the Dcoll bit ,
reset the DCack bit on the next frame pulse, and
restart the counting process. The remainder of the
packet in the Tx FIFO is ignored.
After successfully completing a transmission, the
internal priority level is reduced from high to low.
The internal priority will only be increased once the
terminal co unt for the respec tive level of priority has
been achieved (e.g., if TE has high priority internally
and externally, it must count 8 consecutive ones in
the D-echo channel. Once this is achieved and
successful transmission has been completed, the
internal priority is reduced to a lower level (i.e., count
= 9). This terminal will not return to the high internal
priority until 9 consecutive ones have been
monitored o n th e D-e c ho ch an ne l ) .
9-43
Page 10
MT8930C Preliminary Informatio n
(2)
Signals from NT to TE Signals from TE to NT
Info0
Info2
Info4
No Signal
Valid frame structure with
all B, D, D-echo and A bits
set to ‘0’
Valid frame with data in B,
D, D-echo channels. Bit A is
set to 1.
TE State Activation Diagram
DR = 1
Info0 No Signal
Info1 Continuous Signal of +‘0’, -‘0’
Info3 V a lid frame with data in B & D
AR = 1
and six ‘1’s
Bits
Activation Request
send Info1 if BA = 0
send Info0 if BA = 1
Where: BA
(1)
Note 1: signal is not timebase locked to NT.
Note 2: Sync/BA bit of the Status Register
Sync = 1
= Bus Activity
DR = Deactivation Request
AR = Activation Request
(2)
= Frame Sync Signal
Sync
A = Activation bit
Time out = 32 ms Timer Signal
is configured as Sync bit when
AR = 1 and DR = 0, or as BA bit
when AR = 0 or DR = 1. A change in
the state of the AR and/or DR bits
will cause a change in the function
of the Sync/BA bit in the following
ST-BUS frame.
BA = 0
Deactivated
send Info0
NT State Activation Diagram
Pending
Activation
send Info2
DR = 1
BA = 0
BA = 1
AR = 1
Sync = 1
Sync = 0
Sync = 1
Activated
send Info3
Deactivated
send Info0
DR = 1
AR = 1
Activated
send Info4
Figure 7 - Link Activatio n Protocol, State Di agram
Line Wiring Configuratio n
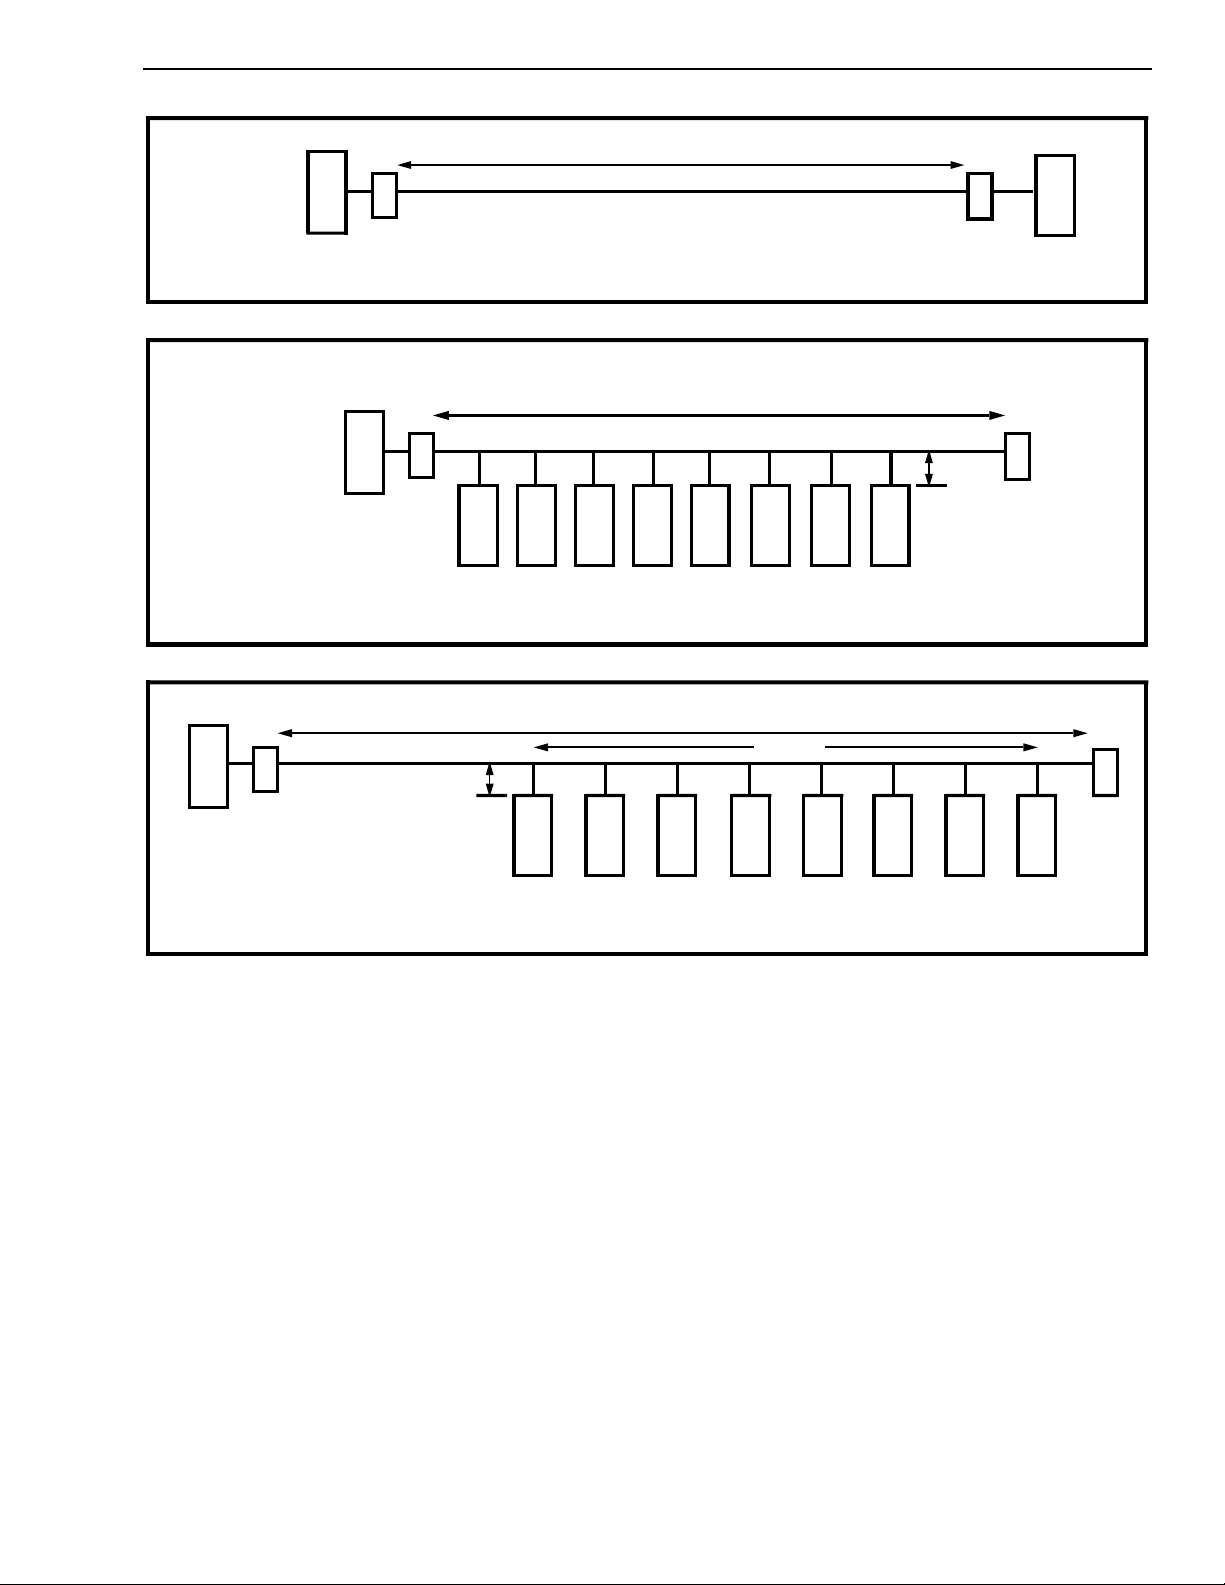
The MT8930C can interface to any of the three
wiring configurations which are specified by CCITT
Recommendation I.430 and ANSI T1.605 (refer to
Figs. 8 to 1 0). These co nsist of a point -to-point or
one of the two point-to-multipoint configurations (i.e.,
short passive bus or the extended passive bus). The
selection of line configurations is performed using
the timing bit (B4 of NT Mode Control Register).
For the short passive bus, TE devices are connected
at random points along the cable. However, for the
extended passive bus all connection points are
grouped at the far end of the cable from the NT.
Synchronized
send Info3 if Sync = 1
DR = 1
A = 1 &
Sync = 1
BA =0
send Info0 if Sync = 0
Sync = 0
A = 0
Time out
Pending
Deactivation
Send Info0
DR = 1
For an NT SNIC in fixed timing mode, the VCO and
Rx filters/peak detectors are disabled and the
threshold vo ltage is fixed. Howev er, for a TE SNIC
or an NT SNIC (i n adaptive timing mode), the VCO
and Rx filters/peak detectors are enabled. In this
manner, the device can compensate for variable
round trip delays and line attenuation using a
threshold voltage set to a fixed percentage of the
pulse peak amplitude.
Another operation can be implemented using the
SNIC in the star configuration as shown in Figure 14.
This mode allows multiple NTs, with physically
independent S-Busses, to share a common input
source and transfer information down the S-Bus to
9-44
Page 11
Preliminary Information MT8930C
0 - 1 Km
NT
NT is operating in adaptive timing
TR is the line termination resistor = 100 Ω
T
R
Figure 8 - Point-to-Point Conf igurati on
NT
NT is operating in fixed timing
TR is the line termination resistor = 100 Ω
T
R
Fiure 9 - Short Passive Bus Configuratio n, up to 8 TEs can be support ed
NT
T
R
0 - 10 m
100 m for 75 Ω impedance cable and 200 m for 150 Ω impedance cable
100 - 200 m
0 - 10 m
TE TE TE TE TE TE TE
TE
0-500 m
0-50 m
T
R
TE
T
R
T
R
TE TE TE TE TE TE TE
NT is operating in adaptive timing
TR is the line termination resistor = 100 Ω
Figure 10 - Extended Passive Bus Configuration, up to 8 TEs can be supported
all TEs . All NT devices connected into the star will
receive the i nformation transmi tted by all TEs on al l
branches of the sta r, exactly as if th ey were on the
same physical S-Bus. All NTs in the star
configuration mu st be ope rat ing in fi xed timing mode.
Refer to the description of the star configuration in
the ST-BUS section.
The SNIC has on e last mode of operati on called th e
NT slave mode. T his has th e effect of op erati ng th e
SNIC in network termination mode (CK/NT pin = 1)
but having the frame structure and registers
description defined by the TE mode. This can be
used where multiple subscriber loops must carry a
fixed phase relation between each line. A typical
situation is when the system is trying to synchronize
two nodes of a synchronous network. This allows
multiple TEs to share a common ST-BUS timebase.
The synchronization of the loops is established by
using the clock signals produced by a local TE as an
input timing source to the NT slave.
TE
Adaptive Timing Operation
On power-up or after a r ese t, t he SNIC in N T mo de is
set to operate in fixed timing. To switch to adaptive
timing, th e use r s h ou ld :
1) set the DR b it to 1
2) set the Timing bit to 1 in the C-channel
Control Register
3) wait for 100 ms period
4) proceed in using the AR and DR bits as
desired
Switching from adaptive timing mode is completed
by resetting the Timing bit.
9-45
Page 12
MT8930C Preliminary Informatio n
125 µs
Channel0Channel1Channel
2
Bit 7 Bit 6 Bit 5 Bit 4 Bit 3 Bit 2 Bit 1 Bit 0
•••
Figure 11 - ST-BUS Stream Forma t
F0b
C4b
ST-BUS
BIT CELLS
Channel 31
Bit 0
Channel 0
Bit 7
Figure 12 - Clock & Frame Alignme nt for ST-BUS Streams
ST-BUS Interface
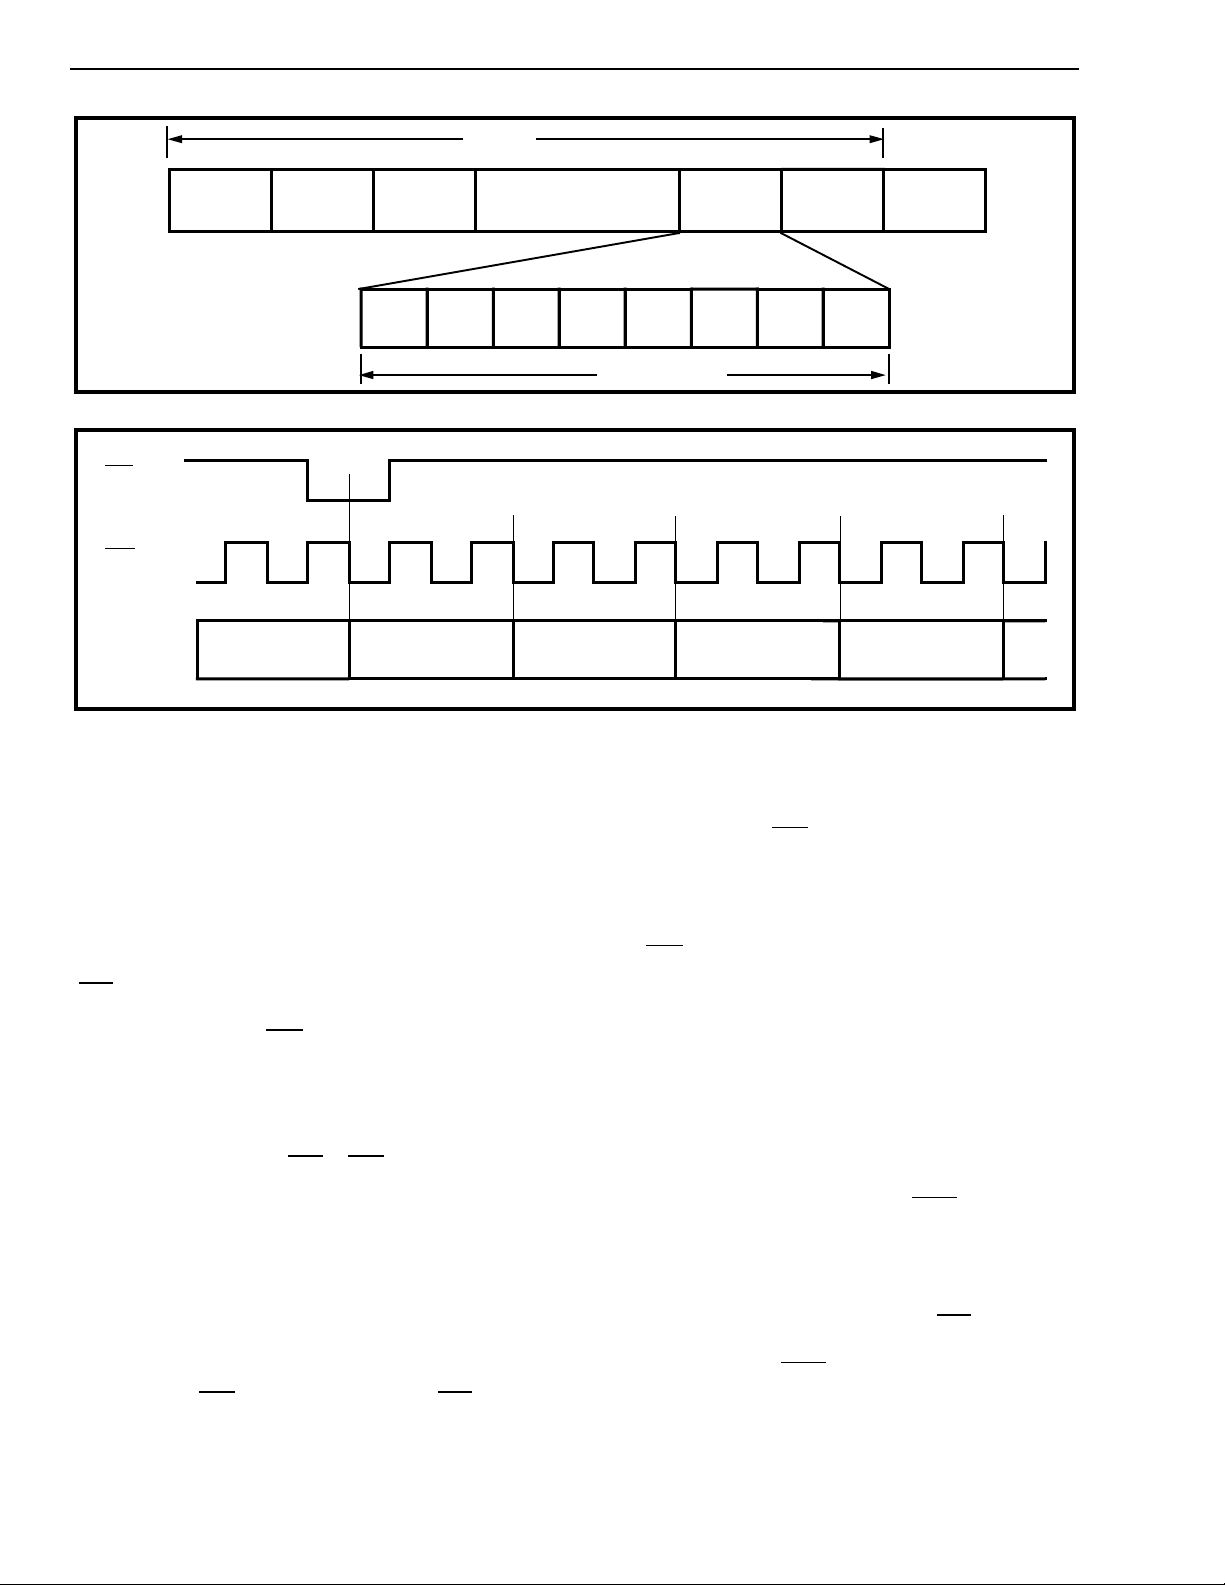
The ST-BUS is a synchronous time division
multiplexed serial bussing scheme with data streams
operating at 2048 kbit/s configured as 32, 64 kbit/s
channels (refer to Fig. 11). Synchronization of the
data transfer is provided from a frame pulse which
identifies the frame boundaries and repeats at an 8
kHz rate. Figure 4 shows how the frame pulse
) defines the ST-BUS frame boundaries. All
(F0b
data is clocke d into the d evice on t he rising edge of
the 4096 kHz clock (C4b
into the bit cell, while data is clocked out on the
falling edge of the 4096 kHz clock at the start of the
bit cell.
All timing signals (i.e. F0b
bidirectional (denoted by the terminating b). The
I/O configuration of these pins is controlled by the
mode of opera tion (NT or TE). In the NT mode, all
synchronized signals are supplied from an external
source and the SNIC uses this timing while
transferring information to and from the S or
ST-BUS. In the TE mode, an on-board analog
phase-locked loop extracts timing from the received
data on the S-Bus and generates the system
4096 kHz ( C4b
) and frame pulse (F0b). The
analog phase-locked loop also maintains proper
phase relatio n between the ti ming signal s as well as
filtering out jitter which may be present on the
received line port.
) three quarters of the way
& C4b) are identified as
(8/2048) ms
Channel 0
Bit 6
Channel30Channel31Channel
Channel 0
Bit 5
0
Channel 0
Bit 4
When the TE mode is selected by tying the CK/NT
pin low, a continuous INFO0 signal on the receiver
will cause the PLL freq uency to drift from it s nomin al
4.096 MHz v alue (C4b
output). Hence, transmitted
INFO1 from the TE will not be at 192 kbps as
required in I. 430 an d T1.605. Howev er, if the user ’s
application requires the transmission of INFO1 at
exactly 192 kbit/s or the presence of an exact 4.096
MHz C4b
clock at all times , then a 4.096 MHz clock
should be connect ed to th e CK/N T pin.
This input clock serve s to co nfigu re th e devic e in TE
mode and to train the PLL in the absence of an
INFO2 or INFO4 signal on the line.
The SNIC uses the first four channels on the
ST-BUS (as shown in Figure 4). To simplify the
distribution of the serial stream, the SNIC
provi des a delay ed fr ame pu lse (F0od
) to eliminate
the need for a channel assignment circuit. This
signal is used to drive subsequent devices in the
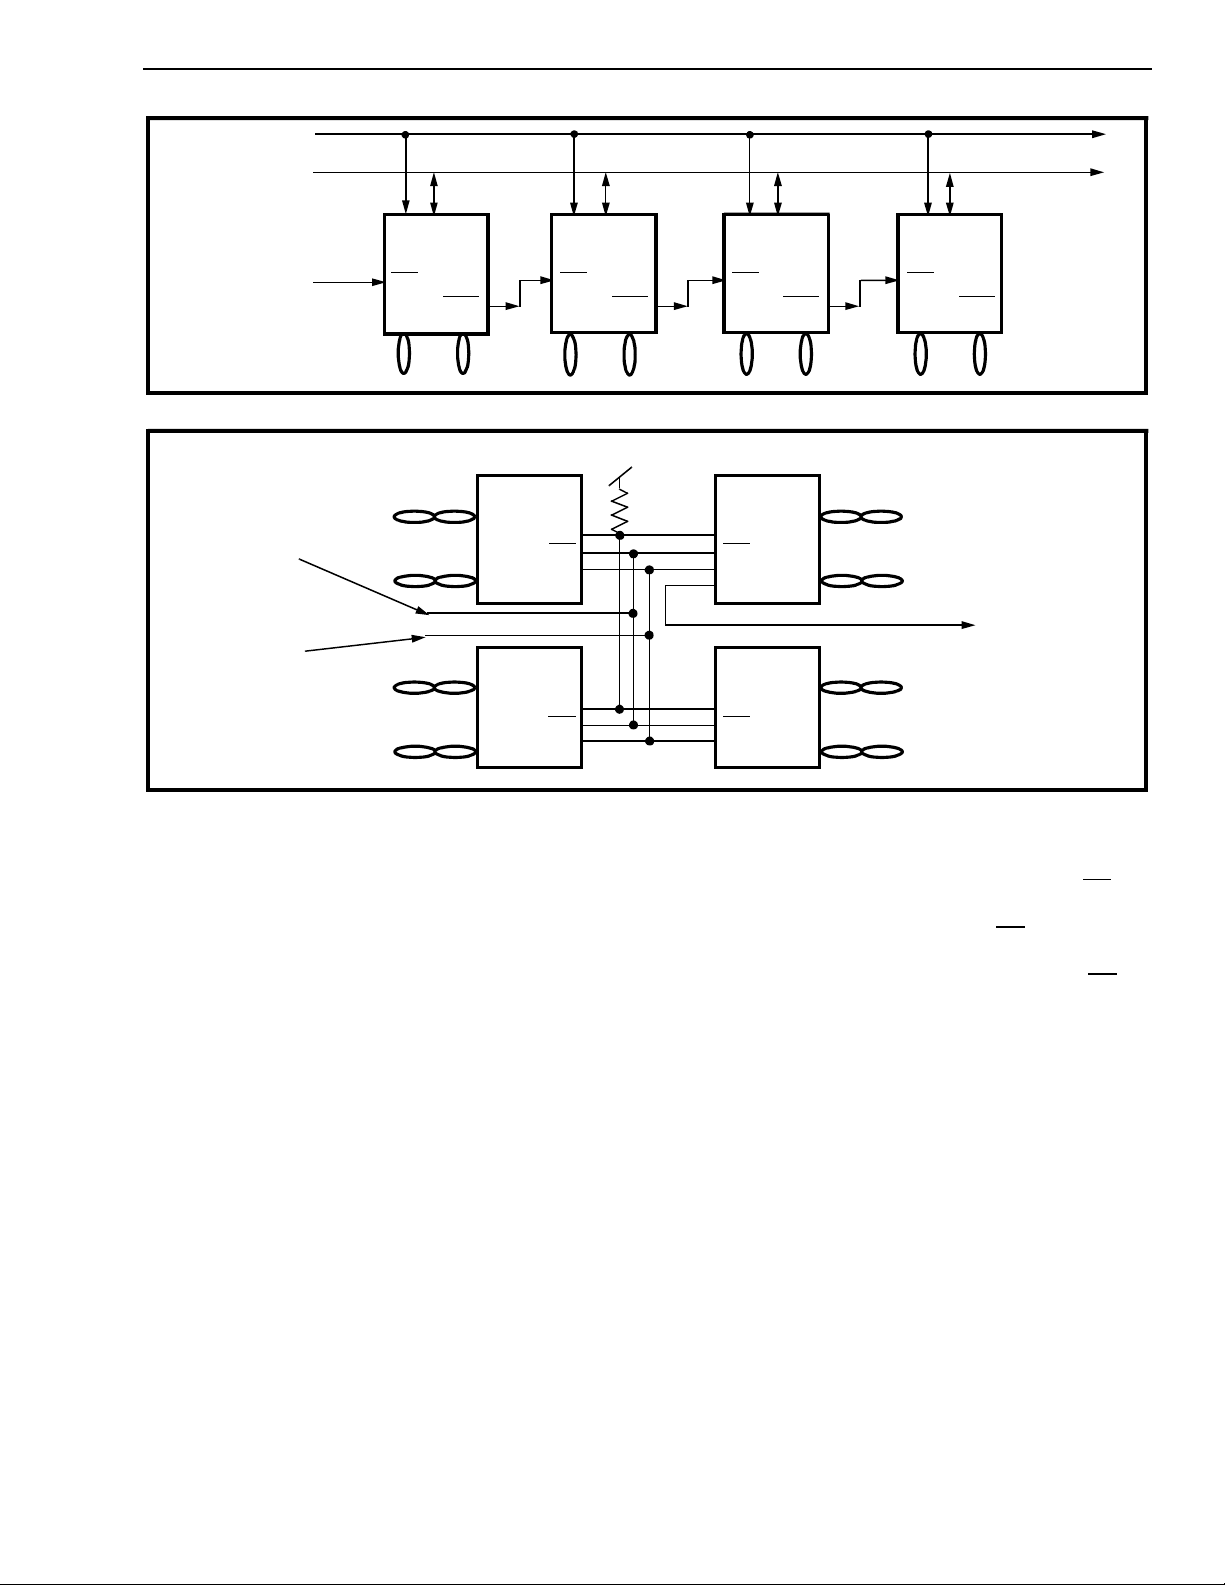
daisy chain (refer Figure 13). In this type of
arrangement, only the first SNIC in the chain will
receive the system frame pulse (F0b
) with the
following devices rece ivi ng i ts p rede ces sor’s del aye d
output fram e pu lse (F0od
).
The SNIC makes efficient use of its TDM bus
through the Star configuration. It does so by sharing
four common ST-BUS channels to multiple NT
devices.
9-46
Page 13
Preliminary Information MT8930C
ST-BUS Clock
ST-BUS
Stream
System
Frame Pulse
System
Frame Pulse
Input
ST-BUS Stream
Active on
Channel 0 - 3
MT8930C
NT
F0b
F0od
to TE to TE to TE to TE
MT8930C
F0b
Figure 13 - Daisy Chaining the SNIC
MT8930C
NT
to TE
to TE
STAR
F0b
DSTi
MT8930C
NT
STAR
F0b
DSTi
Active on
Channels 4 - 7
NT
F0od
V
DD
MT8930C
NT
F0b
MT8930C
NT
STAR
F0b
DSTi
DSTo
MT8930C
NT
STAR
F0b
DSTi
Active on
Channels 8 - 11
F0od
Active on
Channels 12 - 15
MT8930C
NT
F0b
F0od
to TE
Output
ST-BUS Stream
to TE
Figure 14 - NT in Star Config uration
Up to eight SNICs in NT mode with physically
independent S-Busses can be connected in parallel
to realize a star configuration, as shown in Figure 14.
All devices connected into the star will carry the
same input, thus information is sent to all TEs
simultaneously. The 2B+D data received from every
TE is transmitted to all NTs through the STAR pin.
Consequently, all the DSTo streams will carry
identical 2B+D data reflecting what is being
transmitted by th e va r iou s T E s.
The flow of da ta in the d irection o f S-Bus to ST-BUS
is transparent to the SNIC, regardless of the state
machine status. On the other hand, the flow of data
in the direction of ST-BUS to S-Bus becomes
transparent only after the state machine is in the
active state (IS0, IS1 =1, 1), in case of an NT, or in the
synchroniza ti on s t at e ( IS 0, I S1 = 1), i n c as e o f a T E.
Microprocessor/Control Interface
The parallel port on the SNIC operates as either a
general purpose microprocessor interface or as a
hardwired control port.
In microprocessor control mode (Cmode = 1), the
parallel port is compatible with either Motorola or
Intel multiplexed bus signals and timing. The
MOTEL circuit (MOtorola and InTEL
Compatible bu s ) us e s the le v el of the DS /RD
pin
at the rising edge of AS/ALE to select the
appropriate bus timing. If DS/RD
is low at the
rising edge of AS/ALE (refer Fig. 26) then Motorola
bus timing is selected. Conversely, if DS/RD
is
high at the rising edge of AS/ALE (refer Figs. 24 &
25), then Intel bus timing is selected. This has the
effect of redefining the microprocessor port
transparen tly to th e use r.
In this mode, the user has the option of writing to the
C-channel Control or Diagnostic Register through
the parallel port interface or through the C-channel
on DSTi. Bit 0 of the Master Control Register
provides this opti on.
The parallel port on the SNIC allows complete
control of the HDLC transceiver and access to all
data, control and status registers. The internal
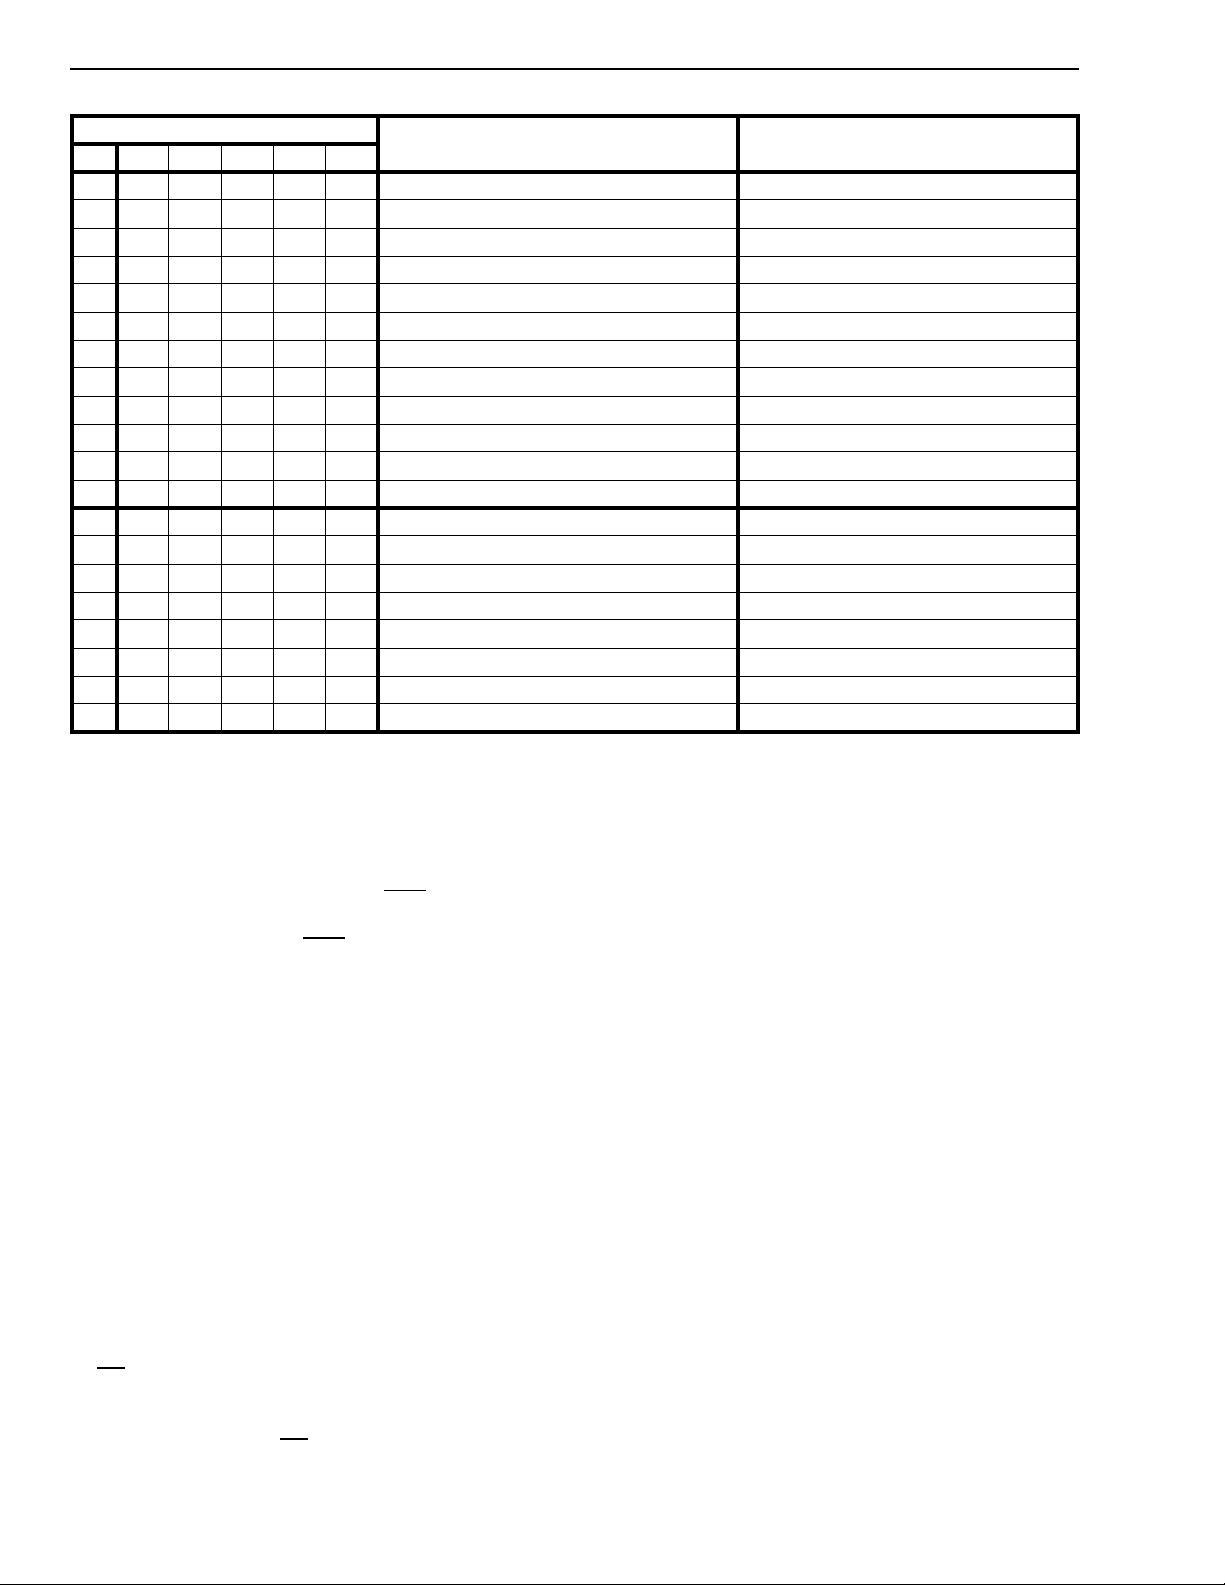
registers (defined in Table 2) can be accessed
through the microprocessor port only when the
Cmode pin is held high. Reading these registers
allows the microprocessor to monitor incoming data
on the S or ST-BUS without interrupting the normal
data flow.
9-47
Page 14
MT8930C Preliminary Informatio n
Address Lines
A4 A3 A2 A1 A0
0 0 0 0 0 Master Control Register verify
A 0 0 0 0 1 ST-BUS Control Register verify
S 0 0 0 1 0 HDLC Control Register 1 verify
Y 0 0 0 1 1 HDLC Control Register 2 HDLC Status Register
N 0 0 1 0 0 HDLC Interrupt Mask Register HDLC Interrupt Status Register
C 0 0 1 0 1 HDLC Tx FIFO HDLC Rx FIFO
0 0 1 1 0 HDLC Address Byte #1 Register verify
0 0 1 1 1 HDLC Address Byte #2 Register verify
0 1 0 0 0 C-channel Control Register
0 1 0 0 1 C-channel Status Register
1 0 0 0 0 Control Register 1 Not available
1 0 0 1 0 Not Available Master Status Register
0 1 0 0 0 DSTi C-channel
01001 DSTo C-channel
S0 1 0 1 0 S-Bus Tx D-channel DSTi D-channel
Y 0 1 0 1 1 DSTo D-channel S-Bus Rx D-channel
N 0 1 1 0 0 S-Bus Tx B1-channel DSTi B1-channel
C 0 1 1 0 1 DSTo B1-channel S-Bus Rx B1-channel
0 1 1 1 0 S-Bus Tx B2-channel DSTi B2-channel
0 1 1 1 1 DSTo B2-channel S-Bus Rx B2-channel
Table 2. SNIC Address Map
Write Read
Some registers are classified as asynchronous and
others as synchronous. Synchronous registers are
single-buffered and require synchronous access.
Not all the synchronous registers have the same
access times, but all can be accessed synchronously
in the time during which the NDA
(refer to Fig. 5). Therefore, it is recommended that
the user make use of the NDA
registers. Since the synchronous registers use
common circuitry, it is essential that the register be
read before being written. This sequence is
important as a write cycle will overwrite the last data
received. These parallel accesses must be refreshed
every frame. Asynchronous registers, on the other
hand, can be accessed at any time.
When the Cmode pin is low, controllerless mode is
selected and the parallel port reverts to hardwired
control/status pins. This allows the MT8930C to
function without the need for a controlling
microprocessor. In the controllerless mode, the
parallel bus has direct connection to the relevant
control/status registers (refer to Pin Description).
Discrete logic can be used to drive/sense
the respective pins. In this mode, pin 11
determines whether the microport pins or
(P/SC
the C-channel bits on DSTi stream are the control
source of the device. If the C-channel is selected
to be the source, P/SC
microport pins are ignored and the C-channel is
loaded into th e C - cha nn el C on tr o l Re gi s t er.
signal to access these
is tied low, then the
signal is low
The data in TE or NT Mode Status Register,
depending upon the mode selected, is always sent
out on the C-channel of DSTo. However, in
microproces sor control mo de the user can overwrite
this data by writing to the DSTo C-channel Register.
This access can be done anytime outside the frame
pulse interv al of the ST-BUS frame. Data writt en in
the current S T-BUS frame wil l only appear in t he Cchannel of the following frame.
The least significant bit (B0) of the C-channel
Register, selects between the control register or the
diagnostic register. Setting the B0 of the C-channel
Register to ’0’ allow access to the control register.
Setting the LSB of t he C-ch an ne l Re gist e r to ’ 1’ a llo w
access to the d iagnostic reg ister. The interpretati on
of each register is defined in Tables 13 and 14 for NT
mode or Tables 16 and 17 for the TE mode.
It is important to note that in TE mode, the C-channel
Diagnostic Register should be cleared while the
device is not in the active state (IS0, IS1
is accomplished by setting the ClrDia bit of the Cchannel Control Register to 1 until the device is
activated. In serial control mode, the C-channel on
the ST-BUS is loaded into the C-channel Control
Register in every ST-BUS frame; the user should
make sure that a 1 is written to the ClrDia bit in every
frame. However, in parallel control mode the user
needs to set the ClrDia bit only once to keep the
≠ 1,1). This
9-48
Page 15
Preliminary Information MT8930C
Diagnostic Regi ster cleared. Once full activati on is
achieved the Diagnostic Register can be written to in
order to enable the various test functions.
HDLC Transceiver
The HDLC Transceiver handles the bit oriented
protocol structure and formats the D-channel as per
level 2 of the X.25 packet switching protocol defined
by CCITT. It transmits and receives the packetized
data (information or control) serially in a format
shown in Figure 15, while providing data
transparency by zero insertion and deletion. It
generates and de tec ts the flag s, var iou s link ch anne l
states and the abort sequence. Further, it provides a
cyclic redundancy check on the data packets using
the CCITT defined polynomial. In addition, it can
recognize a single byte, dual byte or an all call
address in the received frame. There is also a
provision to disable the protocol functions and
provide transparent access to either serial port
through the microprocessor port. Other features
provided by the HDLC include, independent port
selection for transmit and received data (e.g.
transmit on S-Bus and receive from ST-BUS),
selectable 16 or 64 kbit/s D-channel as well as an
HDLC loopback fro m t he tra ns mi t to th e re cei ve po rt.
These features are enabled through the HDLC
control registers (see Tables 6 and 7).
HDLC Frame Format
All frames start with an opening flag and end with a
closing flag as shown in Figure 1 5. Between these
two flags, a frame contains the data and the frame
check sequence (FCS).
ii) Data
The data field refers to the Address, Control and
Information fields defined in the CCITT
recommendations. A valid frame should have a data
field of at least 16 bits. The first and second byte in
the data field is the address of the frame.
iii) Frame Check Sequence (FCS)
The 16 bits following the data field are the frame
check seque nce bit s. The ge ne rator pol ynomi al is :
G(x)=x
16+x12+x5
+1
The transmitter calculates the FCS on all bits of the
data field and transmits the complement of the FCS
with most significant bit first. The receiver performs
a similar computation on all bits of the received data
but also includes the FCS field. The generating
polynomial will assure that if the integrity of of the
transmitted data was maintained, the remainder will
have a consistent pattern and this can be used to
identify, with high probability, any bit errors occurred
during transmission. The error status of the received
packet is ind icated by B7 and B6 bits in the HDLC
Status Reg i st er.
iv) Zero Insertion and Dele tion
The transmitter, while sending either data from the
FIFO or the 16 bits FCS, checks the transmission on
a bit-by-bit basis and inserts a ZERO after every
sequence of fiv e cont ig uous ONEs (includ i ng the la s t
five bits of FCS) to ensure that the flag sequence is
not imitated. Similarly the receiver examines the
incoming frame content and discards any ZERO
directly foll owi ng the five co ntig uous ONE s.
FLAG D ATA FIELD FCS FLAG
One
Byte
n Bytes
(n ≥ 2)
Two
Bytes
One
Byte
Figure 15 - Frame Format
i) Flag
The flag is a unique pattern of 8 bits (01111110)
defining the frame boundary. The transmit section
generates the fl ags and ap pends them automa tically
to the frame to be transmitted. Th e receive section
searches the incoming packets for flags on a
bit-by-bit basis and establishes frame
synchronization. The flags are used only to identify
and synchronize the received frame and are not
transferred to the FIFO.
v) Abort
The transmitter aborts a frame by sending a zero
followed by seven consecutive ONEs. The FA bit in
the HDLC Control Re gist er 2 alo ng with a write to the
HDLC Transmit FIFO enables the transmission of an
abort sequence instead of the byte written to the
register (to ha ve a vali d abort there mus t be at leas t
two bytes in the packet). On the receive side, a
frame abort is defined as s even or more con tiguous
ONEs occurring after the start flag and before the
end flag of a packet. An interrupt can be generated
on reception of the abort sequence using FA bit in
the HDLC Interrupt Mask/Vector Registers (refer to
Tables 9 and 10).
9-49
Page 16
MT8930C Preliminary Informatio n
Interframe Time Fill
When the HDLC Tranceiver is not sending packets,
the transmitter ca n be i n one of two states mentioned
below depending on the status of the IFTF bit in the
HDLC Control Register 1.
i) Idle State
The Idle state is defined as 15 or more contiguous
ONEs. When the HDLC Protocoller is observing this
condition on th e receiv ing chan nel, the Id le bit in the
HDLC Status Registe r is set HIGH. On the transmi t
side, the Protocoller ends the transmission of all
ones (idle state) when data is loaded into the
transmit FIFO.
CCITT I.430 Specification requires every TE that
does not have layer 2 frames to transmit, to send
binary ONEs on the D-channel. In this manner, other
TEs on the line will have the opportunity to access
the D-channel using the priority mechanism circuitry.
ii) Flag Fill State
The HDLC Protocoller transmits continuous flags
(7E
state when data is loaded into the transmit FIFO.
The reception of the interframe time fill will have the
effect of setting the idle bit in the HDLC Status
Register is set to ’0’.
HDLC Transmitter
On power up, the HDLC transmitter is disabled and
in the idle state. The transmitter is enabled by
setting the TxEN bit in the HDLC Control Register 1.
To start a packet, the data is written into the 19 byte
Transmit FIFO starting with the address field. All the
data must be written to the FIFO in a bytewide
manner. When the data is detected in the transmit
FIFO, the HDLC protocoller will pro cee d in one of the
following ways:
1) If the transmitter is in idle state, the pre sent byte
2) If the transmitter is in the flag fill state, the
) in Interframe Time Fill state and ends this
Hex
of ones is completely transmitted before sending
the opening flag. The data in the transmit FIFO is
then transmitted. A TE transmitting on the Dchannel will use the contention circuitry
described previously in
Mechanism
flag presently being transmitted is used as the
opening flag for the packet stored in the transmit
FIFO.
to access this channel.
D-channel Priority
3) If the HDLC transmitter is in transparent
data mode, the protocol functions are disabled
and the data in the transmit FIFO is transmitted
without a framing structure.
To indicat e that the part icular byte is the last byte of
the packet, the EOP bit i n th e HD LC Con tr o l Re gister
2 must be set befo re the last byte is written into th e
transmit FIFO. The EOP bit is cleared automatically
when the data byte is written to the FIFO. A fter the
transmission of the l ast by te in the pa cket , the fr ame
check sequence (16 bits) is sent followed by a
closing flag . If th ere is any mor e da ta in the t ran smit
FIFO, it is immediately sent after the closing flag.
That is, the closing flag of a packet is also used as
the opening flag the the next packet.
However, CCITT I.430 and ANSI T1.605
Recommendations state that after the successful
transmission of a packet, a TE must lower its priority
level within the specified priority class. The user can
meet this require me nt by lo ad in g t he Tx FI FO wi th no
more than one packet and then waiting for the
DCack bit to go to zero, o r for an HDLC interrupt b y
the TEOP bit in the HDLC I nterrupt Stat us Register,
before attemp ting to load a new packet. If there i s no
more data to be transmitted, the transmitter assumes
the selected link channel state.
During the transmission of either the data or the
frame check sequence, the Protocol Controller
checks the transmitted information on a bit by bit
basis to insert a ZERO after every sequence of five
consecutive ONEs. This is required to eliminate the
possibility of imitating the opening or closing flag, the
idle code or an abort sequence.
i) Transmit Underr un
A transmit underrun occurs when the last byte
loaded into the transmit FIFO was not ‘flagged’ with
the ‘end of pack et’ (EOP) bit and t here are no more
bytes in the FIFO. In such a situation, the Protocol
Controller transmits the abort sequence (zero and
seven ones) and moves to the selected link channel
state.
Conversely, in the event that the tra nsm it FI F O is ful l,
any further writes will overwrite the last byte in the
Transmit FIFO.
ii) Abort Transmission
If it is desired to abort the packet currently being
loaded into th e transmit FIFO, the next byte written
to the FIFO should be ‘flagged’ to cause this to
happen. The FA bit of the HDLC Control Register 2
9-50
Page 17
Preliminary Information MT8930C
must be set HIGH, before writing the next byte into
the FIFO. Thi s bit is clea red automati cally once th e
byte is written to the Transmit FIFO. When the
‘flagged’ byte reaches the bottom of the FIFO, a
frame abort sequence is sent instead of the byte and
the transmitter operation returns to normal. The
frame abort sequence is ignored if the packet has
less then two bytes.
iii) Transparent Data Transfer
The Trans bit (B4) in the HDLC Con trol Register 2
can be set to provide transparent data transfer by
disabling the protocol functions. The transmitter no
longer generates the Flag, Abort and Idle sequences
nor does it in s ert the zeros a n d ca lc ul at e th e F CS .
It should be noted that none of the protocol related
status or interr upt bits are applicable in tran sparent
data transfer state. However, the FIFO related
status and inte rrupt bits are pertinent an d carry the
same meaning as they do while performing the
protocol functions.
HDLC Receiver
After a reset on power up, the receive section is
disabled. Address detection is also disabled when a
reset occurs. If address detection is required, the
Receiver Address Registers are loaded with the
desired address and the ADRec bit in the HDLC
Control Register 1 is set HIGH. The receive section
can then be enabled by RxEN bit in this same
Control Regist er 1. All HDLC int erru pts ar e m aske d,
thus the desired interrupt signal must be unmasked
through the HDLC Inter ru pt Ma sk Re gist er. All active
interrupts are cleared by reading the HDLC Interrupt
Status Registe r.
i) Normal P ack ets
After initialization as explained above, the serial data
starts to be clocked in and the receiver checks for
the idle channel and flags. If an idle channel is
detected, the ‘Idle’ bit in the HDLC Status Register is
set HIGH. Once a flag is detected, the receiver
synchronizes itself in a bytewide manner to the
incoming data stream. The receiver keeps
resynchronizing to the flags until an incoming packet
appears. The incoming packet is examined on a
bit-by-bit basis, inserted zeros are deleted, the FCS
is calculated and the data bytes are written into the
19 byte Rece ive FI FO. How ever, the FCS an d othe r
control characters, i.e., flag and abort , are never
stored in th e Re cei ve F IFO. If the add res s det ect ion
is enabled, the address field following the flag is
compared to the bytes in the Receive Address
Registers. If one byte address recognition is
enabled, the address field is one byte long and it is
compared with the six most significant bits in
address recognition register 1. If two byte address
recognition is enabled, the address field is two bytes
long and is compared with the address recognition
registers 1 and 2. The address byte can also be
recognized if it is an all call address (i.e., seven most
significant bits are 1). If a match is not found, the
entire packet is ignored, nothing is written to the
Receive FIFO and the receiver waits for the next
packet. If the active addre s s byte is vali d, the packe t
is received in normal fashion.
All the bytes written to the receive FIFO are flagged
with two status bits. The status bits are found in the
HDLC status register and indicate whether the byte
to be read from the FIFO is the first byte of the
packet, the middle of the packet, the last byte of the
packet with good FCS or t he last byte of the packet
with bad FCS. This status indication is valid for the
byte which is to be read fro m the Rece ive FIFO.
The incoming data is always written to the FIFO in a
bytewide manner. However, in the event of data sent
not being a multiple of eight bits, the software
associated with the receiver should be able to pick
the data bits fro m the LSB positions of the last byte
in the received data written to the FIFO. The
Protocoller does not provide any ind i cation as to how
many bits this might be.
ii) Invalid Packets
In TE mode, if there are less than 25 data bits
between the opening and closing flags, the packet is
considered invalid and the data never enters the
receive FIFO (inserted zeros do not form part of the
valid bit count). This is true even with data and the
abort sequence, the total of which is less than 25
bits. The data packets that are at least 25 bits but
less than 32 bits long are also invalid, but not
ignored. They are clocked into the receive FIFO and
tagged as having bad FCS.
In NT mode, however, all the data packets that are
less than 32 bits long are considered invalid. They
are clocked into the receive FIFO with “Bad FCS”
status.
iii) Frame Abort
When a frame abort is received, the EOPD and FA
bits in the HDLC Interrupt Status Register are set.
The last byte o f the aborted packet is written to the
FIFO with a status of “Packet Byte”. If there is more
than one packet in the FIFO, the aborted packet is
9-51
Page 18
MT8930C Preliminary Informatio n
distinguished by the fact that it has no “Last Byte”
status on any of i ts by te s .
iv) Idle Channel
While receiving the idle channel, the idle bit in the
HDLC status register remains set.
v) Tran sparent Data Transfer
By setting the Trans bit in the HDLC Control Register
2 to select the transparent data transfer, the receive
section will disable the protocol functions like Flag/
Abort/Idle detection, zero deletion, CRC calculation
and address comparison. The received data is
shifted in from the active port and written to receive
FIFO in bytewide format.
It should be noted that none of the protocol related
status or interr upt bits are applicable in tran sparent
data transfer state. However, the FIFO related
status and in terrupt bits are pertinent an d carry the
same meaning as they do while performing the
protocol functions.
vi) Receive Overflow
Receive overflow occurs when the receive section
attempts to load a byte to an already full receive
FIFO. All attempts to write to the full FIFO will be
ignored until the receive FIFO is read. When
overflow occurs, the rest of the present packet is
ignored as the receiver will be disabled until the
reception of the next opening flag.
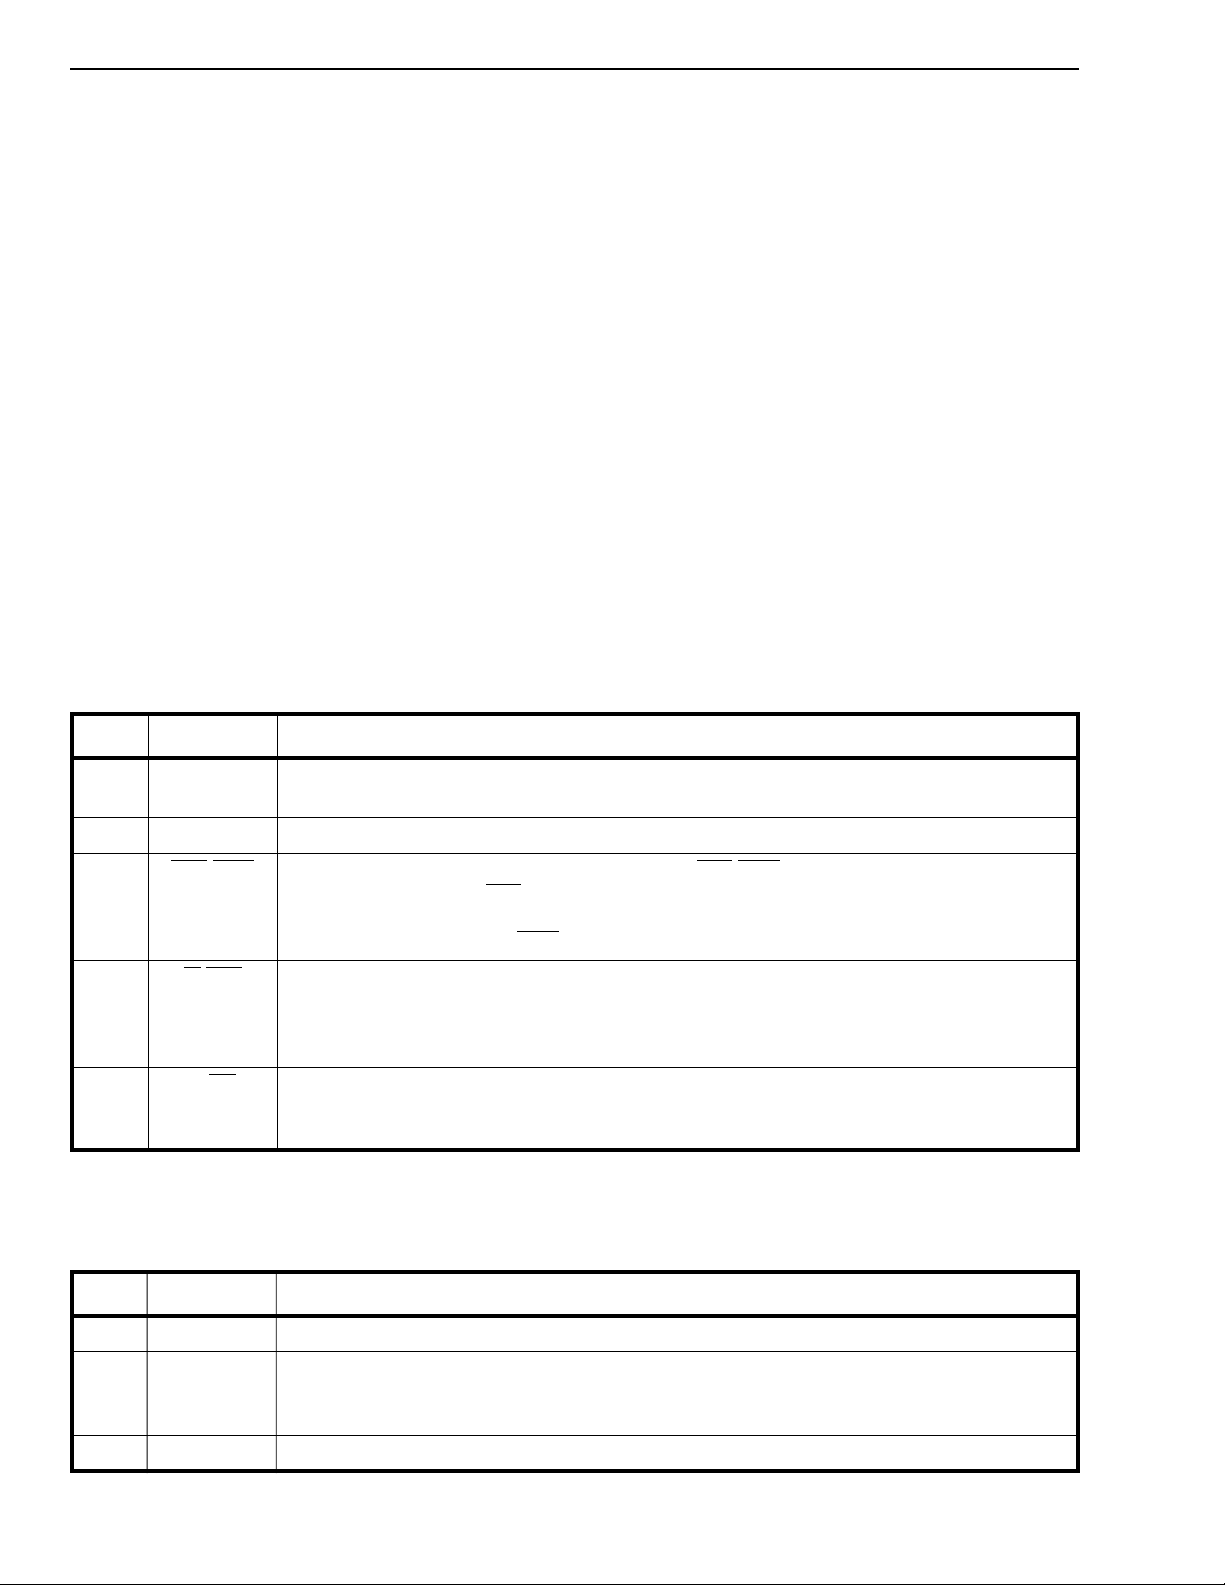
BIT NAME DESCRIPTION
B7 NA A ‘1’ will allow access to Control Register 1 and Master Status Register.
A ‘0’ will prevent it.
B6-B3 NA
B2 IRQ
(1)
Keep at ’0’ for normal operation.
/NDA The state of this pin will select the mode of the IRQ/NDA pin.
A ’0’ will enable the IRQ
pin for HDLC interrupts.
A ’1’ will enable the New Data Available signal which identifies the access time to the
is enabled, the HDLC interrupts are disabled.)
(2)
or S bit as selected in the NT Mode C-channel
B1 M
synchronous registers. (If NDA
/Sen A ’0’ will enable the transmission of the M
Register (refer to Table 13). The selection of M or S is determined by the HALF signal
(refer to functional timing).
A ’1’ will disable this feature forcing the M and S bits to binary zero.
B0 P/SC
The Parallel/Serial Control bit selects the source of the control channel. If ’0’, then the Cchannel Register is access through the ST-BUS stream. If ’1’, then the C-channel
Register is accessed through the microprocessor port.
Table 3. Master Control Register (Read/Write Add. 00000
Note 1: These bits have no designated memory space and will read as the last v alues written to the microprocesso r port.
Note 2: The transmission of M=1 is used for a second level of multiframing.
)
B
BIT NAME DESCRIPTION
B7 NA Keep at ‘0’ for normal operation.
B6 RxDIS When set to ‘1’, this bit disables the S-Bus signal receiver. It can be used, for example, to
force INFO4 to INFO2 transition in the NT state machine while receiving INFO3 from the
TE.
B5-B0 NA Keep at ‘0’ for normal operation.
Table 4. Control Register 1 (Write Add. 10000
9-52
)
B
Page 19
Preliminary Information MT8930C
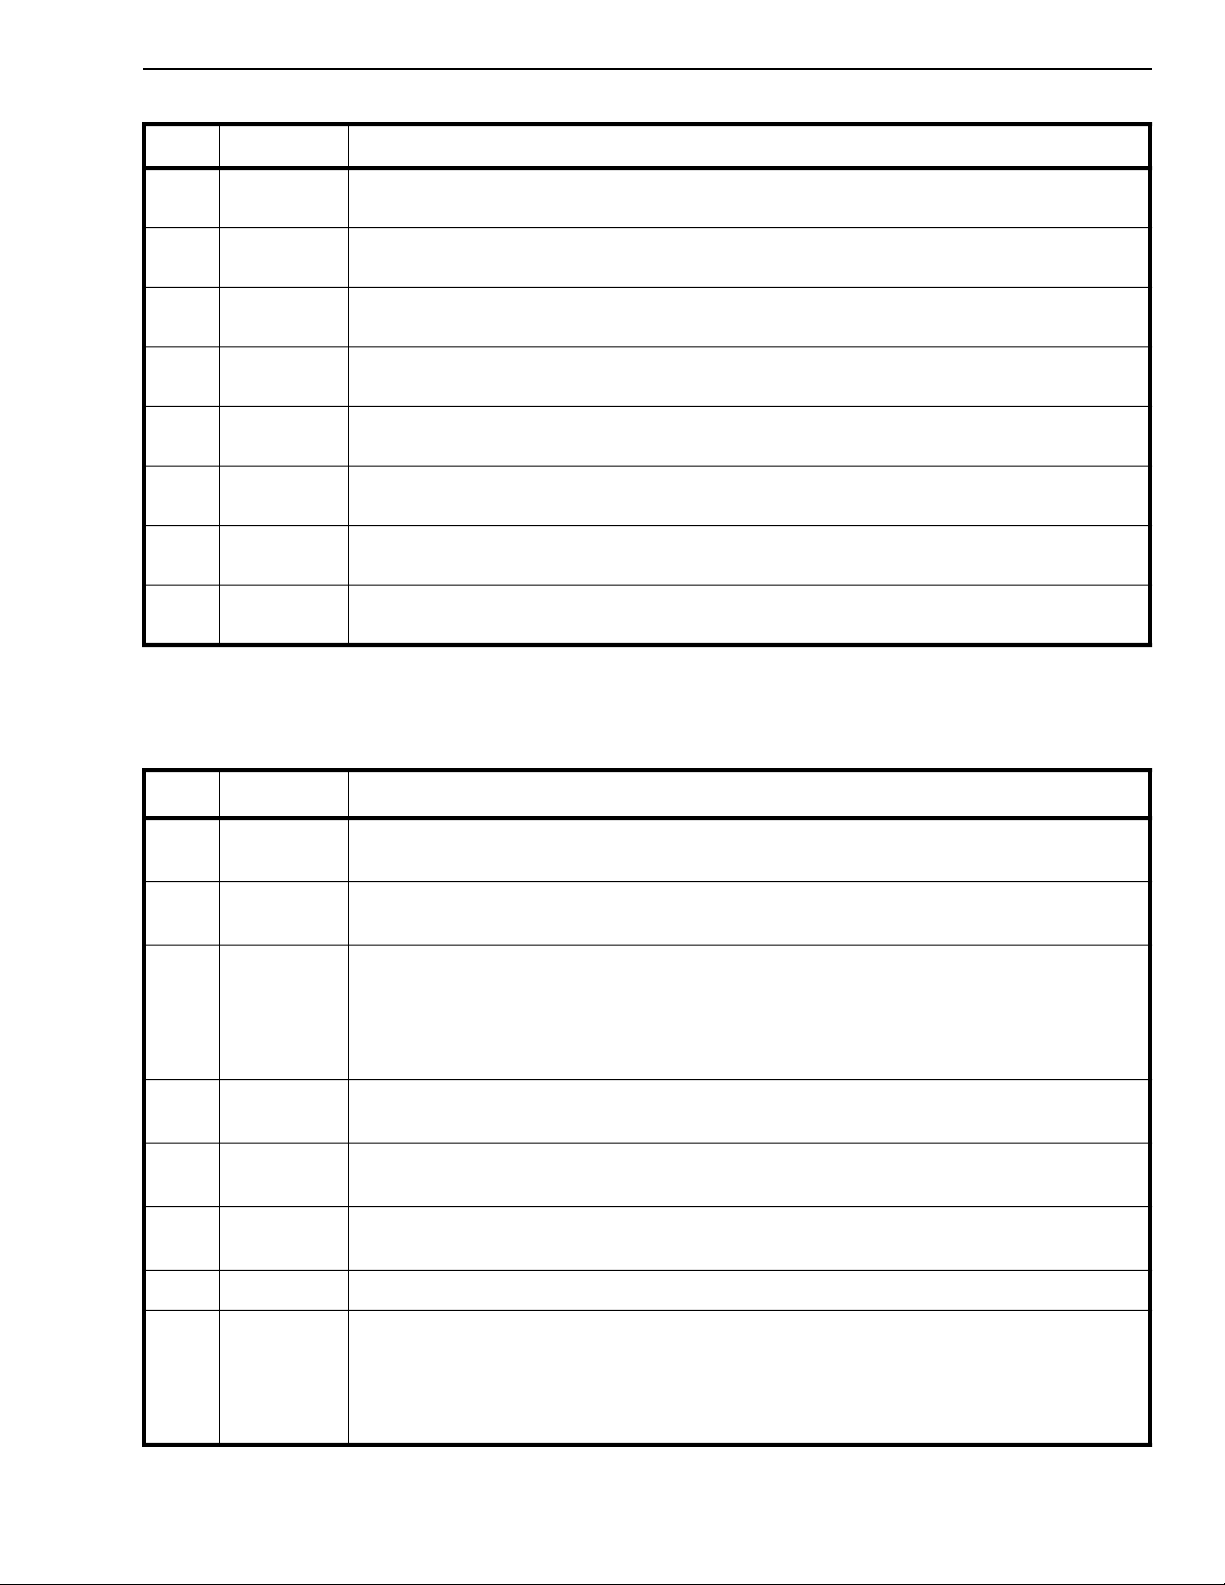
BIT NAME DESCRIPTION
B7 CH3i
B6 CH2i
B5 CH1i
B4 CH0i
B3 CH3o
B2 CH2o
B1 CH1o
B0 CH0o
Note 3: All ST-BUS channels are enabled in controllerless mode.
(3)
If ’1’, then the ST-BUS channel 3 input port is enabled (B2-channel).
If ’0’, then the channel is disabled, and will read FF
(3)
If ’1’, then the ST-BUS channel 2 input port is enabled (B1-channel).
If ’0’, then the channel is disabled, and will read FF
(3)
If ’1’, then the ST-BUS channel 1 input port is enabled (C-channel).
If ’0’, then the channel is disabled, and will read 00
(3)
If ’1’, then the ST-BUS channel 0 input port is enabled (D-channel).
If ’0’, then the channel is disabled, and will read FF
(3)
If ’1’, then the ST-BUS channel 3 output port is enabled (B2-channel).
.
H
.
H
.
H
.
H
If ’0’, then the channel is disabled and it will be placed in High impedance.
(3)
If ’1’, then the ST-BUS channel 2 output port is enabled (B1-channel).
If ’0’, then the channel is disabled and it will be placed in High impedance.
(3)
If ’1’, then the ST-BUS channel 1 output port is enabled (C-channel).
If ’0’, then the channel is disabled and it will be placed in High impedance
(3)
If ’1’, then the ST-BUS channel 0 output port is enabled (D-channel).
If ’0’, then the channel is disabled and it will be placed in High impedance.
Table 5. ST-BUS Control Register (Read/Write Add. 00001
)
B
BIT NAME DESCRIPTION
B7 TxEn A ’1’ enables the HDLC transmitter for the selected D-channel (i.e., ST-BUS or S-Bus).
A ’0’ disables the HDLC transmitter (i.e., an all 1s signal will be sent).
B6 RxEn A ’1’ enables the HDLC receiver for the selected D-channel (i.e., ST-BUS or S-Bus).
A ’0’ disables the HDLC receiver (i.e., an all 1s signal will be received).
B5 ADRec If ’1’, then the address recognition is enabled. This forces the receiver to recognize only
those packets having the unique address as programmed in the Receive Address
Registers or if the address byte is the All-Call address (all 1s).
If ’0’, then the address recognition is disabled and every valid packet is stored in the
received FIFO.
B4 TxPrtSel This bit selects the port of the HDLC transmitted D-channel.
A’1’ selects the S-Bus port. A ’0’ selects the ST-BUS port.
B3 RxPrtSel This bit selects the port of the HDLC received D-channel.
A ’1’ selects the S-Bus port. A ’0’ selects the ST-BUS port.
B2 IFTF This bit selects the Inter Frame Time Fill.
A ’1’ selects continuous flags. A ’0’ selects an all 1’s idle state.
B1 NA Keep at ’0’ for normal operation.
B0 HLoop A ’1’ will activate the HDLC loopback where the transmitted D-channel is looped back to
the received D-channel
(1)
. In NT mode, the transmission of the packet is not affected. In
TE Mode, however, the DReq bit of C-channel Control Register must be set to ‘1’ for the
packet to be transmitted to the S-Bus.
A ’0’ disables the loopback.
Table 6. HDLC Control Register 1 (Read/Write Add. 00010
Note 1: The HDLC receiver must be enabled as well as the designated channel.
)
B
9-53
Page 20
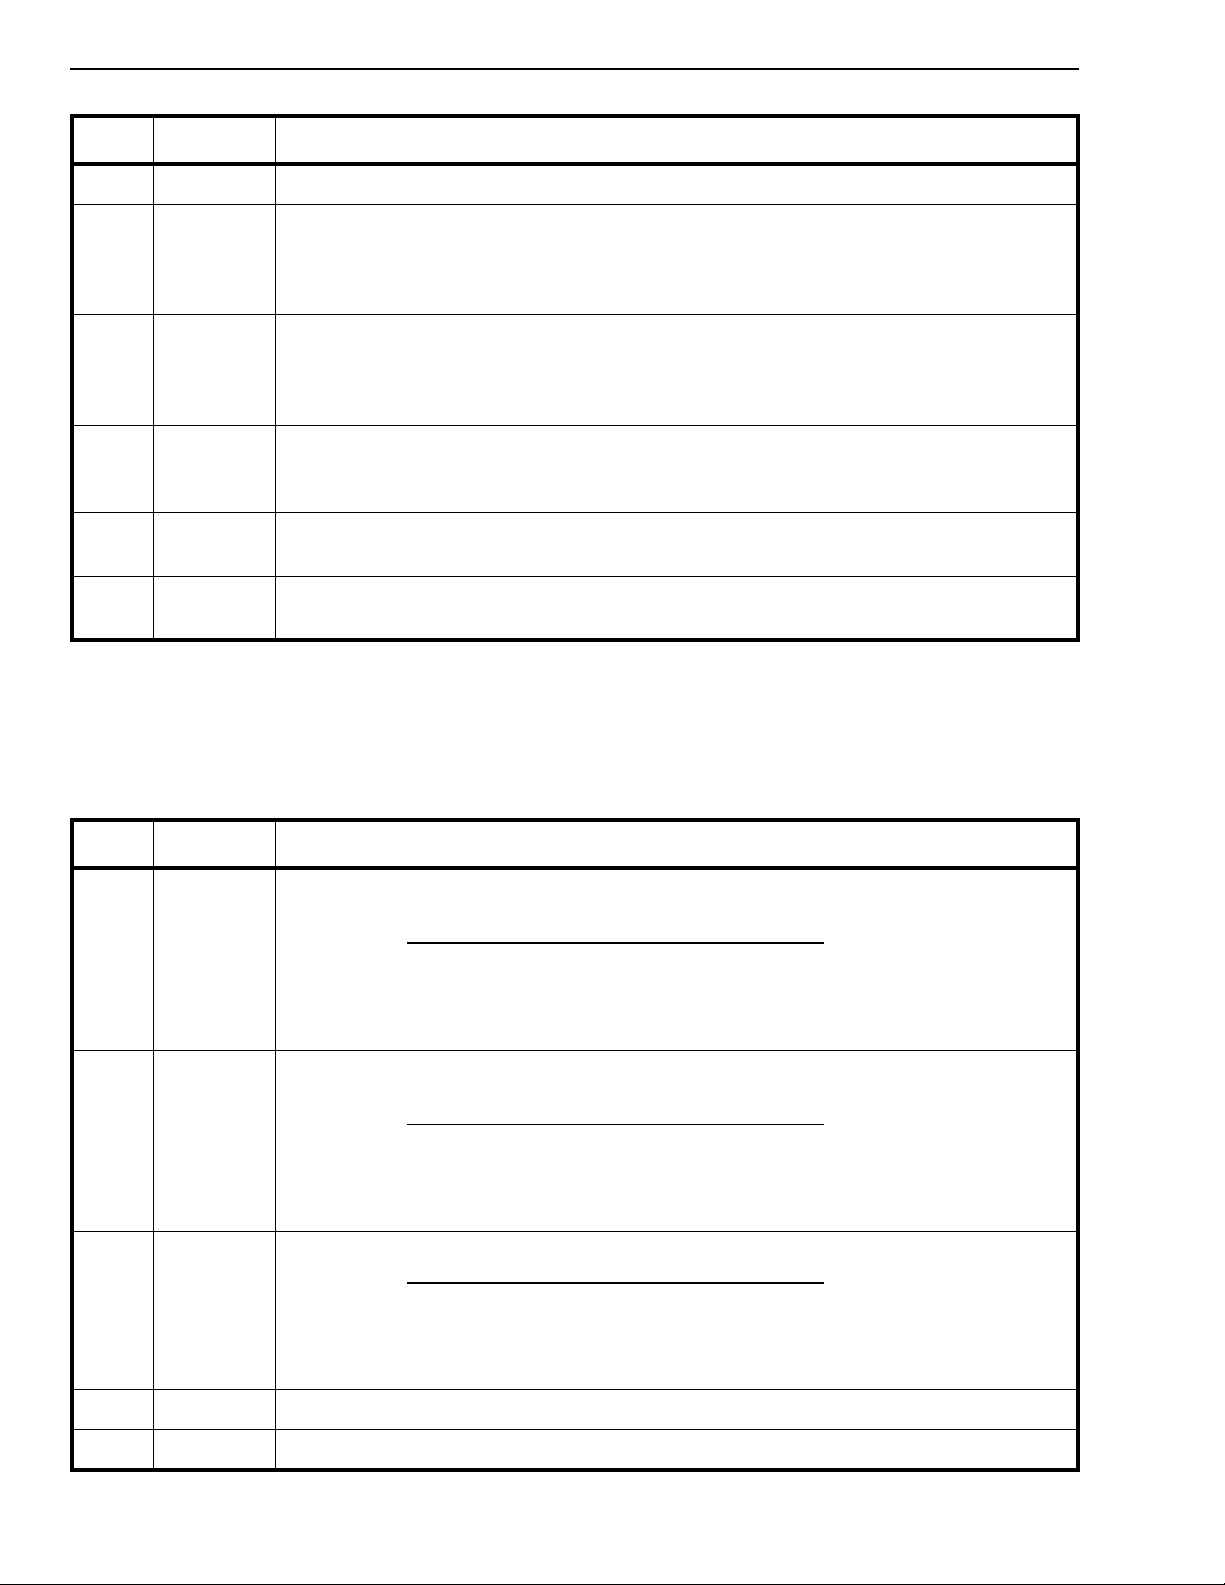
MT8930C Preliminary Informatio n
BIT NAME DESCRIPTION
B7-B5 NA Keep at ’0’ for normal operation.
B4 Trans A ’1’ will place the HDLC in a transparent mode. This will perform the serial to parallel or
parallel to serial conversion without inserting or deleting the opening and closing flags,
CRC bytes or zero insertion. The source or destination of the data is determined by the
port selection bits in the HDLC Control Register 1.
B3 RxRst A transition from ‘0’ to ’1’ will reset the receive FIFO. This causes the receiver to be
disabled until the reception of the next flag. (The status Register will identify the RxFIFO
as being empty). The device resets this bit to ‘0’ immediately after clearing the receive
FIFO.
B2 TxRst A transition from ‘0’ to ’1’ will reset the transmit FIFO. This causes the transmitter to
clear all data in the TxFIFO. The device resets this bit to ‘0’ immediately after clearing
the transmit FIFO.
B1 FA
B0 EOP
(2)
(2)
A ’1’ will ’tag’ the next byte written to the transmit FIFO and cause an abort sequence to
be transmitted once it reaches the bottom of the FIFO.
A ’1’ will ’tag’ the next byte written to the transmit FIFO and cause an end of packet
sequence to be transmitted once it reaches the bottom of the FIFO.
Table 7. HDLC Control Register 2 (Write Add. 00011
Note 2: These bits will be reset after a write to the TxFIFO
BIT NAME DESCRIPTION
B7-B6 RxByte
Status
These two bits indicate the status of the received byte which is ready to be read from the
19 deep received FIFO. The status is encoded as follows:
B7 -B6
0 - 0 - Packet Byte
0 - 1 - First Byte
1 - 0 - Last Byte (Good FCS)
1 - 1 - Last Byte (Bad FCS)
B5-B4 RxFIFO
Status
These two bits indicate the status of the 19 deep receive FIFO. This status is encoded
as follows:
B5 - B4
0 - 0 - Rx FIFO Empty
0 - 0 - ≤14 Bytes
1 - 0 - Rx FIFO Overflow
1 - 1 - ≥15 Bytes
)
B
B3-B2 TxFIFO
Status
These two bits indicate the status of the 19 deep transmit FIFO as follows:
B3 - B2
0 - 0 - Tx FIFO Full
0 - 1 - ≥5 Bytes
1 - 0 - Tx FIFO Empty
1 - 1 - ≤ Bytes
B1 Idle If ’1’, an idle channel state has been detected.
B0 Int If ’1’ an unmasked asynchronous interrupt has been detected.
Table 8. HDLC Status Register (Read Add. 00011
9-54
)
B
Page 21
Preliminary Information MT8930C
BIT NAME DESCRIPTION
B7 EnDcoll A ’1’ will enable the D-channel collision interrupt.
A ’0’ will disable it. This bit is available only in TE mode.
B6 EnEOPD A ’1’ will enable the received End of Packet interrupt.
A ’0’ will disable it.
B5 EnTEOP A ’1’ will enable the transmit End of Packet interrupt.
A ’0’ will disable it.
B4 EnFA A ’1’ will enable the Frame Abort interrupt.
A ’0’ will disable it.
B3 EnTxFL A ’1’ will enable the Transmit FIFO Low interrupt.
A ’0’ will disable it.
B2 EnTxFun A ’1’ will enable the Transmit FIFO Underrun interrupt.
A ’0’ will disable it.
B1 EnRxFF A ’1’ will enable the Receive FIFO Full interrupt.
A ’0’ will disable it.
B0 EnRxFov A ’1’ will enable the Receive FIFO Overflow interrupt.
A ’0’ will disable it.
Table 9. HDLC Interrupt Mask Register (Write Add. 00100
)
B
BIT NAME DESCRIPTION
(1)
B7 Dcoll
A ’1’ indicates that a collision has been detected on the D-channel (i.e., received E-bit
does not match with transmitted D-bit). This bit is available only in TE mode and when the
HDLC transmitter is enabled. It always reads ’0’ in NT mode.
(1)
B6 EOPD
A ’1’indicates that an end of packet has been detected on the HDLC receiver. This can be
in the form of a flag, an abort sequence or as an invalid packet.
(1)
B5 TEOP
A ’1’ indicates that the transmitter has finished sending the closing flag of the last packet in
the Tx FIFO, and the internal priority level is reduced from high to low.
B4 FA
(1)
A ’1’ indicates that the receiver has detected a frame abort sequence on the received data
stream.
B3 TxFL
(1)
A ’1’ indicates that the device has only four Bytes remaining in the Tx FIFO. This bit has
significance only when the Tx FIFO is being depleted and not when it is getting loaded.
(1)
B2 TxFun
A ’1’ indicates that the Tx FIFO is empty without being given the ’end of packet’ indication.
The HDLC will transmit an abort sequence after encountering an underrun condition.
(1)
B1 RxFF
A ’1’ indicates that the HDLC controller has accumulated at least 15 bytes in the Rx
FIFO.
B0 RxFov
(1)
A ’1’ indicates that the Rx FIFO has overflown (i.e., an attempt to write to a full Rx FIFO).
The HDLC will always disable the receiver once the receive overflow has been detected.
The receiver will be re-enabled upon detection of the next flag.
Table 10. HDLC Interrupt Status Register (Read Add. 00100
Note 1: All interrupts will be reset after a read to the HDLC Interrupt Status Register.
)
B
9-55
Page 22
MT8930C Preliminary Informatio n
BIT NAME DESCRIPTION
B7-B2 R1A7-R1A2 A six bit mask used to interrogate the first byte of the received address (where B7 is MSB).
If address recognition is enabled, any packet failing the address comparison will not be
stored in the Rx FIFO.
B1 NA Not applicable to address recognition.
B0 A1En If ’0’, the first byte of the address field will not be used during address recognition.
If ’1’ and the address recognition is enabled, the six most significant bits of the first
address byte will be compared with the first six bits of this register.
Table 11. HDLC Address Recognition Register 1 (Read/Write Add. 00110
BIT NAME DESCRIPTION
B7-B1 R2A7-R2A1 A seven bit mask used to interrogate the second byte of the received address (where B7 is
MSB). If address recognition is enabled, any packet failing the address comparison will
not be stored in the Rx FIFO. This mask is ignored if the address is a Broadcast (i.e., R2A
= 1111111).
B0 A2En If ’0’, the second byte of the address field will not be used during address recognition.
If ’1’ and the address recognition is enabled, the seven most significant bits of the second
address byte will be compared with the first seven bits of this register.
Table 12. HDLC Address Recognition Register 2 (Read/Write Add. 00111
)
B
)
B
BIT NAME DESCRIPTION
B7 AR Setting this bit will initiate the activation of the S-Bus.
If ’0’, the device will remain in the present state.
B6 DR Setting this bit will initiate the deactivation of the S-Bus.
If ’0’, the device will remain in the present state. This bit has priority over AR.
B5 DinB If ’1’, the D-channel will be placed in the B1 timeslot allocating 64 kbit/s to the D-channel.
If ’0’, the D-channel will assume its position with a 16 kbit/s bandwidth.
(1)
B4 Timing A ’0’ will set the NT in a short passive bus configuration using a fixed timing source (no
compensation for line length).
A ’1’ will set the NT in a point-to-point or extended passive bus configuration with adaptive
timing compensation.
B3 M/S This bit represents the state of the transmitted M/S-bit. M when HALF=0 and S when
HALF=1.
B2 HALF The state of this bit identifies which half of the frame will be transmitted on the S-
Bus. The operation of this signal is similar to that of the HALF pin.
B1 TxMFR A ’1’ in this bit, while HALF = 0, will force the transmission of a multiframe sequence in the
Fa and N bits, i.e., Fa=1 and N=0. A ‘0’ will resume normal operation, i.e., Fa=0 and N=1.
B0 RegSel If the register select bit is set to ’1’, the control register is redefined as the diagnostic
register. A ’0’ give access to the control register.
Table 13. NT Mode C-channel Control Register
Note 1: Allow one ST-BUS frame to input the C-channel and one ST-BUS frame to establish the connection.
Note 2: The C-channel Control Register is updated once every ST-BUS frame. Therefore, this register should not be written to
more than once per frame, otherwise, the last access will over ride previous on es.
(2)
(Write Add. 01000B and B0 = 0)
(1)
9-56
Page 23
Preliminary Information MT8930C
BIT NAME DESCRIPTION
B7-B6 Loop The status of these two bits determine which type of loopback is to be performed:
B7 - B6
0 - 0 - no loopback active
0 - 1 - near end loopback LTx to LRx
1 - 0 - digital loopback DSTi to DSTo
1 - 1 - remote loopback LRx to LTx
B5 FSync If ’1’, the device will maintain frame synchronization even after losing the framing
sequence (i.e., if the device is transmitting INFO2 or INFO4 and this bit is set, the same
INFO signal will still be transmitted even if the frame sync sequence in the received signal
is lost).
If ’0’, synchronization will be declared when three consecutive framing sequences have
been detected without error.
B4 FLv If ’1’, the frame sync sequence will violate the bipolar violation encoding rule.
If ’0’, the framing pattern resumes normal operation, i.e., Framing bit is a bipolar violation.
B3 Idle Setting this bit to ’1’ will force an all 1s signal to be transmitted on the line.
B2 Echo Setting this bit to ’1’ will force all D-echo bits (E) to zero.
B1 Slave If ’1’, the device will operate in a NT slave mode. This allows the device to be used at the
terminal equipment end of the line while receiving its clocks from an external source.
B0 RegSel If the register select bit is set to ’1’, the control register is redefined as the diagnostic
register. A ’0’ gives access to the control register.
Table 14. NT Mode C-channel Diagnostic Register (Write Add. 01000
and B0 = 1)
B
BIT NAME DESCRIPTION
B7 Sync/BA This bit is set when the device has achieved frame synchronization while the activation
request is asserted (DR = 0 and AR = 1). If there is a deactivation request or AR is low
(1)
(DR = 1 or AR = 0), this bit indicates the presence of bus activity
. A bus activity identifies
the reception of INFO frames (INFO1 or INFO3).
B6-B5 IS0-IS1 Binary encoded state sequence.
IS0 - IS1
0 - 0 - deactivated
0 - 1 - pending deactivation
1 - 0 - pending activation
1 - 1 - activated
B4 RxMCH Following a ‘0’ input at the HALF pin or HALF bit in the C-channel Control Register, the
state of this bit reflects the received maintenance Q-channel (received in the Fa bit
position during multiframing).
This bit will always read ‘1’ if multiframing is not used.
B3-B0 NA These bits will read
Table 15. NT Mode Status Register
Note 1: Bus activity is set when three zeros are received in a time period equivalent to 48 bits or 250µs. It is reset when 128
Note 2: The Status Register is updated internally once every ST-BUS frame. Therefore, more than one read access per frame will
consecutive ones are received.
return the same value.
’1’.
(2)
(Read Add. 01001
)
B
9-57
Page 24
MT8930C Preliminary Informatio n
BIT NAME DESCRIPTION
B7 AR Setting this bit will initiate the activation of the S-Bus.
If ’0’, the device will remain in the present state.
B6 DR Setting this bit will initiate the deactivation of the S-Bus.
If ’0’, the device will remain in the present state. This bit has priority over AR.
B5 DinB If ’1’, the D-channel will be placed in the B1 timeslot allocating 64 kbit/s to the
D-channel.
If ’0’, the D-channel will assume its position with a 16 kbit/s bandwidth.
(1)
(1)
B4 Priority The status of this bit selects the priority class of the terminal equipment. A ’1’ selects the
high priority and a ’0’ selects the low priority.
B3 DReq This bit is used to request or relinquish the D-channel on the S-Bus when the D-channel
source is the ST-BUS. A ’1’ will request the D-channel, a ’0’ will relinquish it.
Keep at ’0’ when the D-channel source is the HDLC transmitter.
B2 TxMCH The state of this bit will be transmitted in the maintenance channel (Q-channel).
B1 ClrDia A ’1’ will clear the contents of the Diagnostics Register.
A ’0’ will enable the maintenance functions found in the Diagnostic Register.
This bit should be set to 1 as long as the device is not fully active (IS0, IS1 ≠ 1,1).
B0 RegSel If the register select bit is set to ’1’, the control register is redefined as the diagnostic
Register. A ’0’ gives access to the Control Register.
Ta ble 16. TE M ode C-cha nnel Contro l Registe r
Note 1: Allow one ST-BUS frame to input the C-channel and one ST-BUS frame to establish the connection.
Note 2: The C-c hannel Control Register is updated once ever y ST-BUS frame. Therefore, this register should not be written to
more than once per frame, otherwise, the last access will override previous ones.
(2)
(Write Add. 01000B and B0 = 0)
BIT NAME DESCRIPTION
B7-B6 Loop The status of these two bits determine which type of loopback is to be performed:
B7 - B6
0 - 0 - no loopback active
0 - 1 - near end loopback LTx to LRx
1 - 0 - digital loopback DSTi to DSTo
1 - 1 - remote loopback LRx to LTx
B5 FSync If ’1’, the device will maintain frame synchronization even after losing the frame sync
sequence (i.e., if the device is transmitting INFO3 and this bit is set, INFO3 will still be
transmitted even if the frame sync sequence in the received signal is lost).
If ’0’, synchronization will be declared when three consecutive framing sequences have
been detected.
B4 FLv If ’1’, the frame sync sequence will violate the normal bipolar encoding rule.
If ’0’, the framing pattern resumes normal operation, i.e., framing bit will be a bipolar
violation.
B3 Idle If ’1’, an all 1s signal is transmitted on the line.
If ’0’, the transmitter will resume normal operation.
B2-B1 NA Unused.
B0 RegSel If the register select bit is set to ’1’, the control register is redefined as the diagnostic
register. A ’0’ gives access to the control register.
Table 17. TE Mode Diagnostic Register (Write Add. 01000
and B0 = 1)
B
9-58
Page 25
Preliminary Information MT8930C
BIT NAME DESCRIPTION
B7 Sync/BA This bit is set if the device has achieved frame synchronization while the activation request
is asserted (DR = 0 and AR = 1). If there is a deactivation request or that AR is low ( DR =
1 or AR = 0), this pin indicates the presence of bus activity
reception of INFO frames (INFO2 or INFO4).
B6-B5 IS0-IS1 Binary encoded state sequence.
IS0 - IS1
0 - 0 - deactivated
0 - 1 - synchronized
1 - 0 - activation request
1 - 1 - activated
B4 M/S This bit respresents the state of the received M/S-bit. M when HALF=0 and S when
HALF=1
B3 HALF The state of this bit identifies which half of the S-Bus frame is currently being output on the
ST-BUS.
B2 RxMFR A ’1’ when HALF=0 indicates that the multiframe pattern on Fa and N has been detected.
B1 Priority The status of this bit indicates the internal priority of the device within the designated
priority class. If 1, then it has high priority within the priority class designated in B4 of
control register. If 0, then it has low priority within the priority class designated in B4 of
control register.
(1)
. A bus activity identifies the
B0 DCack A ’1’ indicates that the device has gained access to the D-channel and has transmitted an
opening flag. This bit is reset to ‘0’ when the closing flag of the last packet in the TxFIFO is
transmitted and the internal priority is reduced from high to low. A collision during
transmission will also reset this bit back to ‘0’.
Table 18. TE Mode S tatus Register
Note 1: Bus activity is set when three zeros are received in a time period equivalent to 48 bits or 250µs. It is reset when 128
Note 2: The Status Register is updated internally once every ST-BUS frame. Therefore, more than one read access per frame will
consecutive ones are received.
return the same value.
(2)
(Read Add. 01001
)
B
BIT NAME DESCRIPTION
B7-B2 NA Not available.
B1* INFO1 In TE mode, this bit is set to ‘1’ only when the device is transmitting INFO1.
Not available in NT mode.
B0* INFO0 In NT or TE mode, this bit is set to ‘1’ only when the device is transmitting INFO0.
Table 19. Master Status Register (Read Add. 10010
* These two bits can be used along with status bits IS0 and IS1 to distinguish between states F6/F8 and F4/F5 of the device’s state machine
in TE mode. Please refer to “State Machine” section of Application Note MSAN-141 for further det ails.
)
B
9-59
Page 26
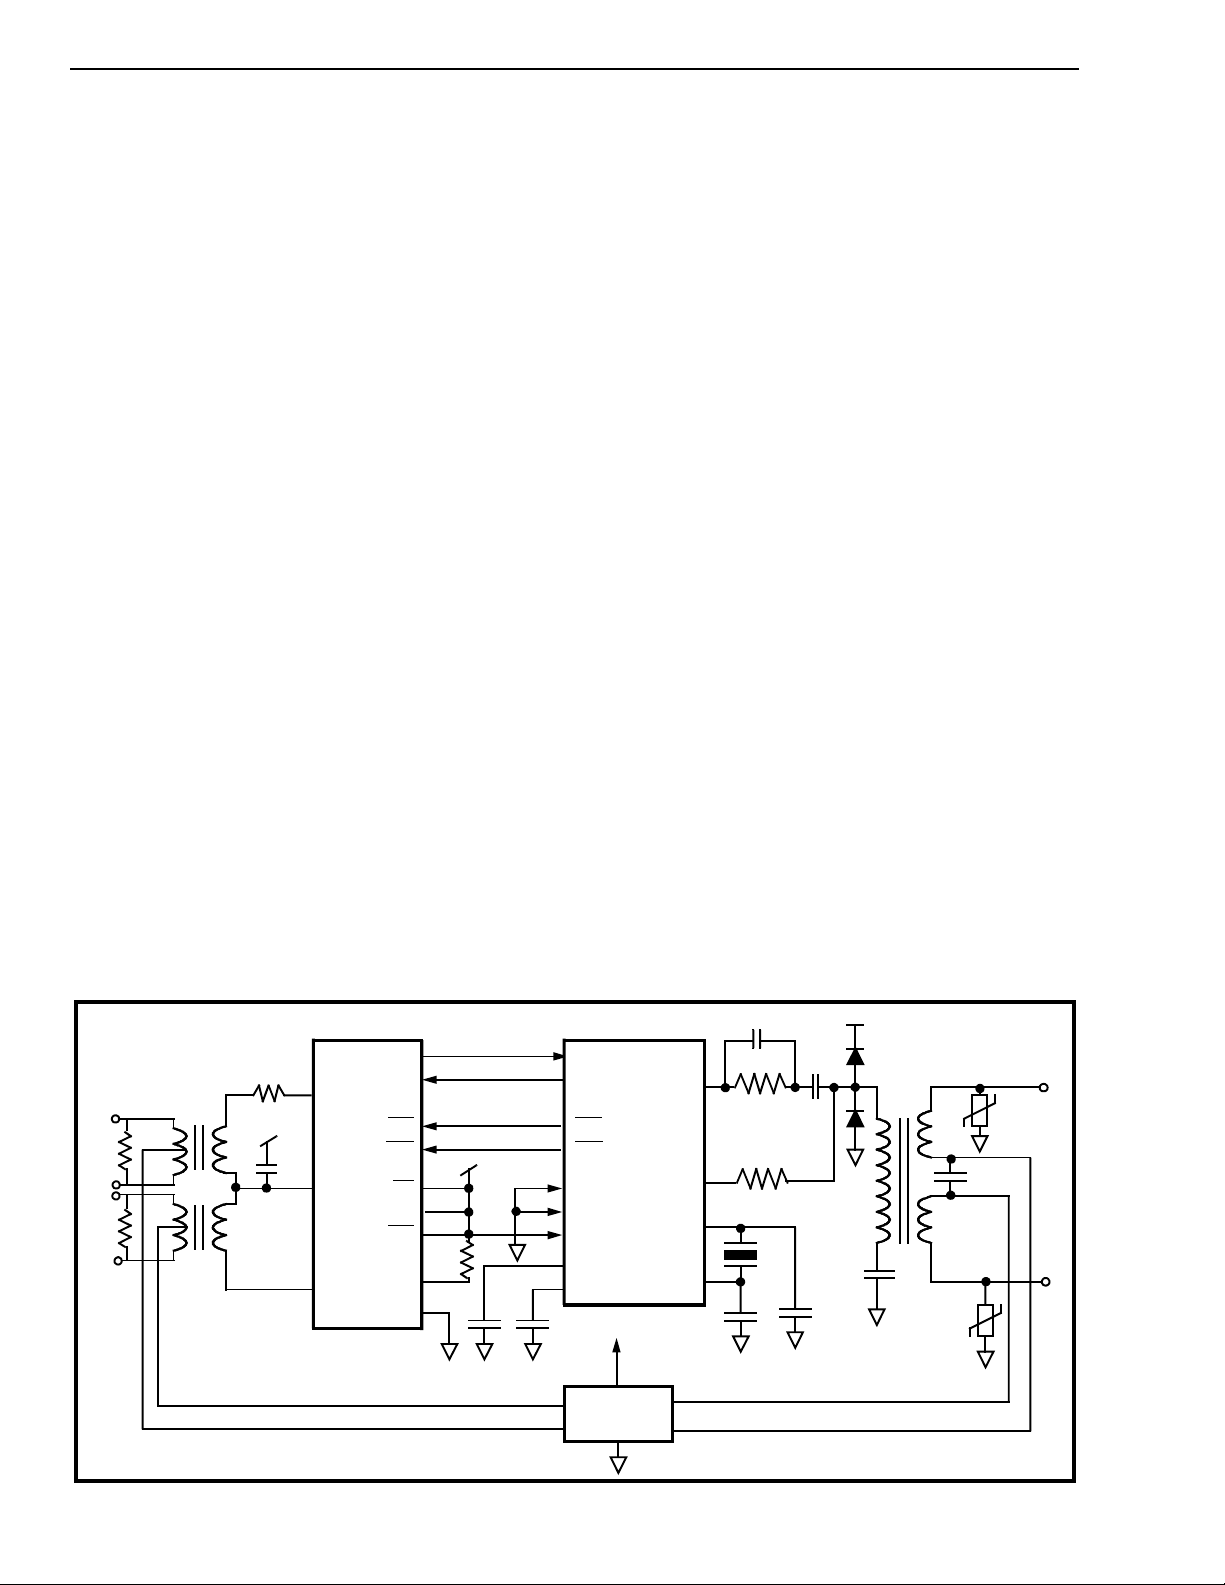
MT8930C Preliminary Informatio n
Applications
The MT8930C is useful in a wide variety of ISDN
applications. Being used at both the Network
Termination (NT) and Terminal Equipment (TE) ends
of the line, the SNIC finds application on digital
subscriber line cards and in full featured digital
telephone sets.
The SNIC can be combined with the MT8971B/72B
to implement an NT1 function(with biphase line code
on the U interface) as shown in Figure 16. It can
also be combined with the MT8910 to implement an
ISDN NT1 function (with 2B1Q line code on the U
interface) a s shown in Figure 17. The MT 8930C is
configured i n NT mode, a cting as a ma ster to the S interface line, while the MT8971B/72B or the
MT8910 operates in slave mode and derives its
timing from the U-interface line originating from the
central office. For Figure 16, communication
between the two devices is done via the serial STBUS ports. Control and status of the SNIC is
communicated with the MT8971B/72B through the
C-channel of the ST-BUS.
Both the MT8930C and MT9094 are controlled and
monitored by a microp roces sor to i mplem ent var ious
features and control functions. Signalling may be
performed by scanning the keypad and generating
appropriate messages to be packetized by the HDLC
section of the SNIC and transmitted via the Dchannel. A twelve segment, non-multiplexed LCD
display can be connected directly to the S12-S1
outputs to provide various status and call progress
indicators.
It must be noted, that the pseudo-ternary line code
will tolerate lin e r eve rsals within the LRx and LTx pair
between the NT and TE. However, reversal of the
TE transmit pair between two or more TEs will make
the S-inter face i n op er a bl e .
In multidrop applications, a powered-off TE must not
load the line and prevent communications between
the NT and other TEs. To avoid such a situation, one
mechanical re lay should be us ed to disconnec t the
LTx pin and th e LR x pi n from the l i ne tr a n sf or m e r s.
Interfacing to Non-Multiplexed Busses
Figure 18 illustrates the use of the SNIC in
conjunction with the MT9094 to implement a 2B+
D, ISDN telephone set. The MT9094 provides such
features as A/D and D/A conversion, handset
interface, ha nds free opera tio n and tone r ing er. PCM
encoded voice is passed from the MT9094 to the
SNIC via the ST-BUS port for transmission on one of
the B-channels. The second B-channel is available
for transmission of data. These two devices have
been designed to connect together with vir tually no
interconnec tio n compo ne nts.
MT8930C MT8971B/72B
LTx
V
LRx
Bias
DSTo
DSTi
F0b
C4b
P/SC
NT
Rsti
Star
C
mode
+5V
10kΩ
0.33 µF
R
Tx
1:2*
‡
R
‡
R
1:2*
+5V
10 µF
The microprocessor interface for the SNIC was
designed around a multiplexed bus architecture
which may be found with most Intel processors/
controllers or a few Motorola processors. In the
event that your choice of processors is restricted, a
simple application circuit can convert the nonmultiplexed bussing to that of a multiplexed
architecture . Figure 19 p rovides an to interface the
MC6802 or the MC6809 microprocessors.
+5V
22 nF
2:1
1.0 µF
0.33 µF
33 pF
DSTi
DSTo
F0b
C4b
MS0
MS1
MS2
V
V
0.33 µF
REF
Bias
+5V
L
OUT
L
OSC1
OSC2
1.5 nF
390 Ω
47 Ω
IN
10.24 MHz XTAL
33 pF
9-60
DC to DC
Converter
Figure 16 - NT1 Function
‡
100Ω terminating resistor
Page 27
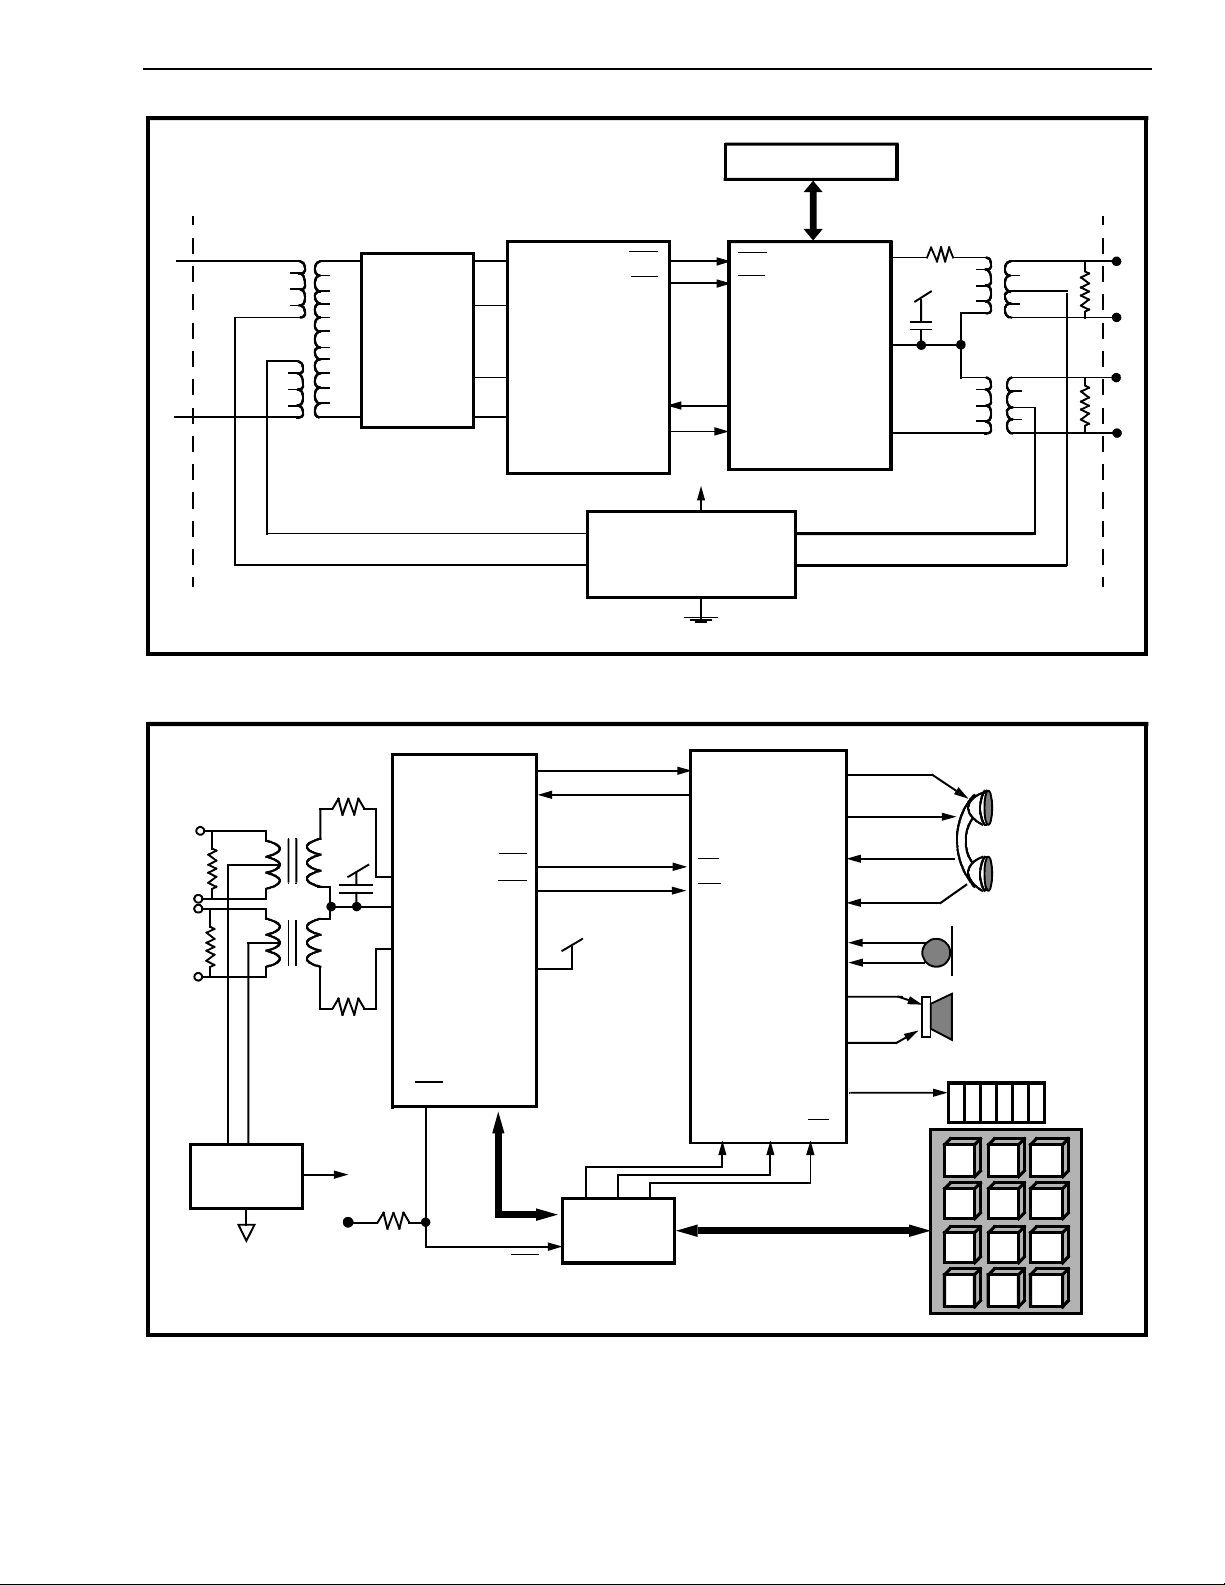
Preliminary Information MT8930C
Microprocessor
U Reference
Point
‡
R
‡
R
Termination
Network
MH89101
L
out+
L
in+
L
in-
L
out-
MT8910-1
DSLIC
C4b
F0b
DSTi
DSTo
C4b
F0b
DSTo
DSTi
MT8930C
NT Mode
V
LTx
Bias
LRx
+5V
Power Supply
and
Power Feed
‡
100Ω terminating resistor
Figure 17 - NT1 using the MT8910-1 (DSLIC) and MT8930C (SNIC)
DSTi
DSTo
F0i
C4i
MT9094
HSPKR+
HSPKR-
M+
M-
MIC+
MIC-
SPKR+
SPKR-
1:2
1:2
R
V
DD
2kΩ
MT8930C
DSTo
Tx
LTx
V
Bias
LRx
DSTi
F0b
C4b
C
mode
V
DD
R
Tx
2:1
V
DD
10µF
‡
R
‡
R
2:1
S Reference
Point
Handset
Microphone
Speaker
DC to DC
Converter
‡
IRQ
+5V
+5V
10k
100Ω terminating resistor
Data Port
DATA1
SCLK
S12-1
CS
8051
IRQ
Figure 18 - ISDN Digital Telephone Set
Display
23
1
456
789
#
0
*
K
e
y
p
a
d
9-61
Page 28
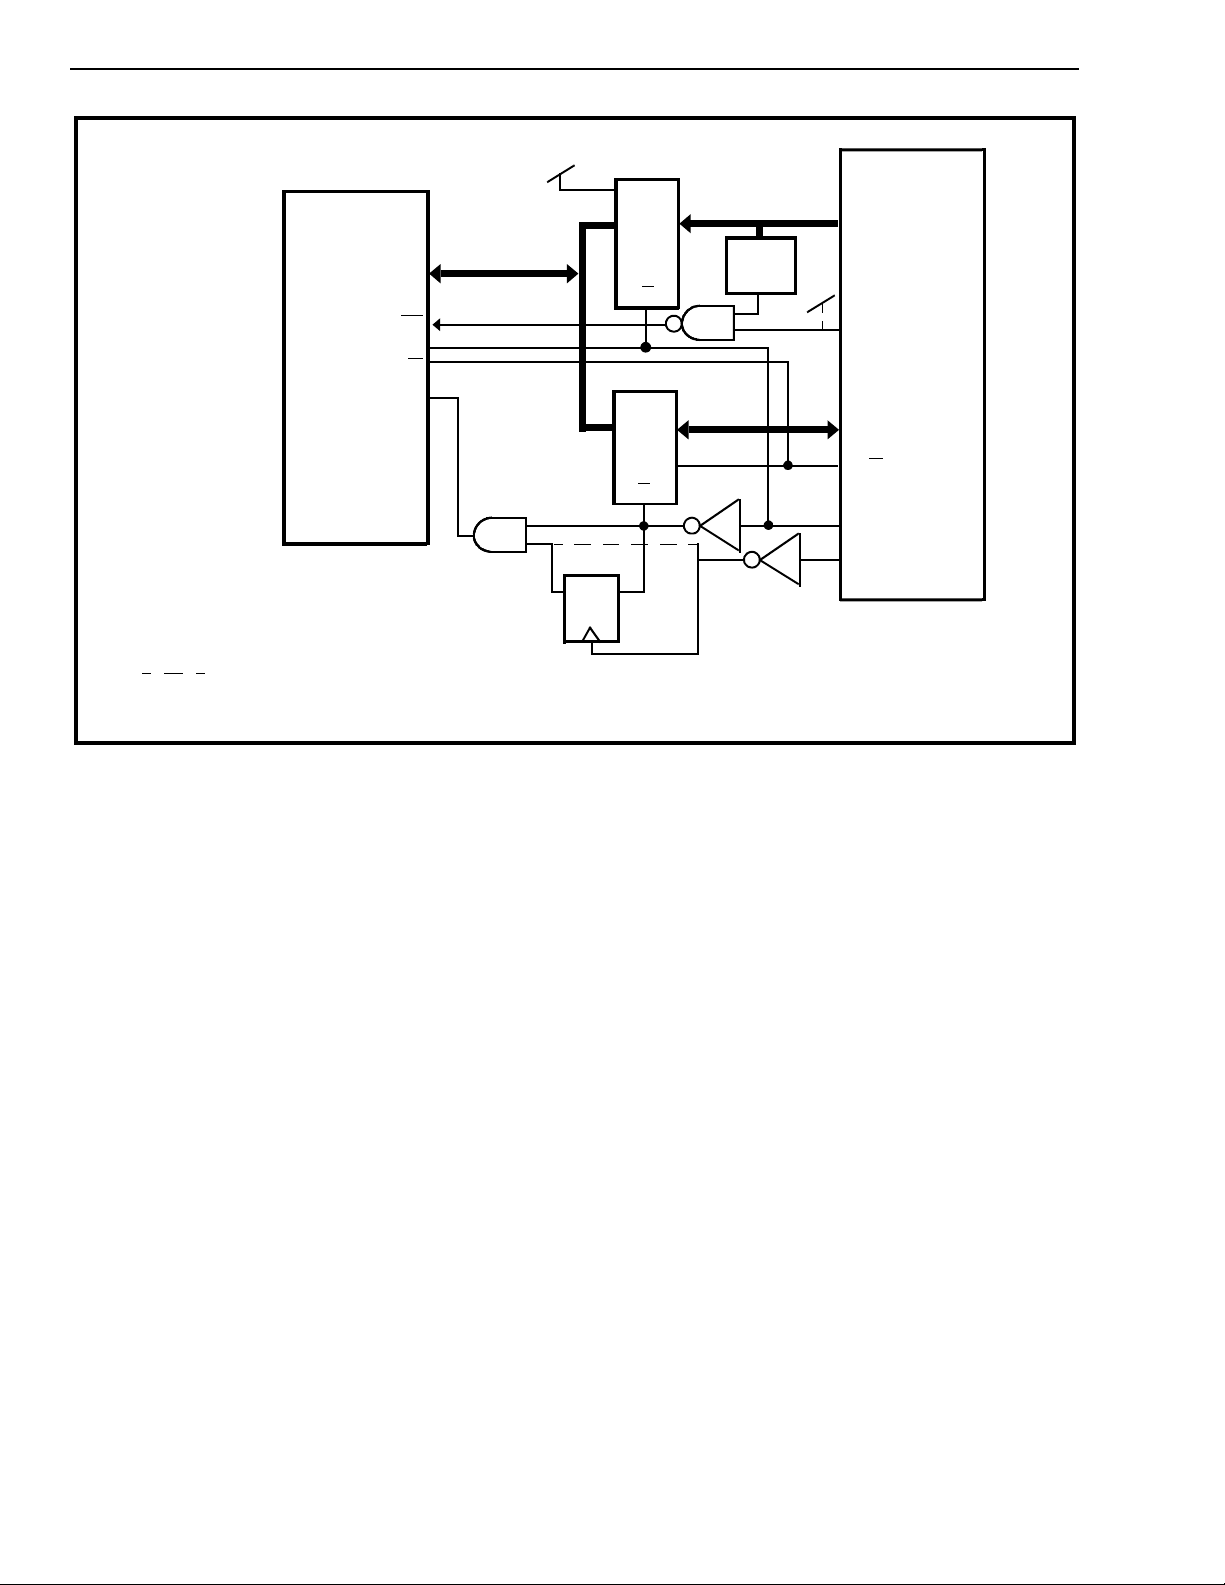
MT8930C Preliminary Informatio n
MT8930C
AD0-AD7
CS
DS
R/W
AS
Connections to interface to MC6809
V
DD
74HCT245
74HCT245
QD
DIR
B
A
G
G
DIR
A
Address
Decoder
B
V
DD
MC6802
(MC6809)
A0 - A7
VMA
D0 - D7
R/W
E
EXTAL (Q)
Figure 19 - Interfacing to the MC6802 Microprocessor
ETS 300-012 NT&TE Line Interface
Figure 20 shows the recommended line interface
circuit for meeting the ETS 300-012 requirements.
This circuit assumes that test measurements are
made using the "standard reference cord" which has
the following specifications:
C = 315pF to 350pF
R = 2.7Ω to 3.0Ω
Z > 75Ω
Length < 10m
In Figure 20, R 1 and D5,6 (germani um) ensure that
the pulse shape lies within the center of the various
pulse templates. D1-4 protect the MT8930C from
line transients. C2,3 decouple the VBias voltage and
optimize the recei ver sen s itivit y. R2 and C4 make up
a lowpass filter recommended for delaying the signal
in TE applications, this filter can also be used for NT
application s allowing common hardwa re for TE and
NT applications. K1 isolates the MT8930C from the
line for multidrop applications in cases where the
device is powere d down. L1 (eg., Filtran CTS4669
or VAC N4025-X034) is a 4-winding 5mH common
mode choke to suppress EMI on the 4-wire line.
T1,2 (Filtran TPW-3852-4) provide isolation,
longitudinal balance, impedance matching and
voltage level conversion.
The TPW-3852-4 is available from:
Filtran Ltd.
229 Colonnade Road
Nepean, Ontario
Canada
Telephone: (613) 226-1626
Proprietary NT&TE Line Interface
For proprietary applications, where stringent
requirements such as ETS 300-012 do not have to
be met, the line interface circuit may be simpler and
consequently les s ex pens ive. Fig ure 21 sho ws s uch
a line interface circuit. R1 should be chosen
according to the transformer selected and the
desired outpu t signal lev el, typica l values of R1 may
vary from 30Ω to 75Ω. Numerous types of
transformers may be used, including the following:
APC 8016D (dual with common mode choke)
Filtran TEW-5660 (surface mount)
Filtran TPW-3852-4 (single)
Pulse PE-65495 (dual)
VAC L4097-X028-80 (single)
9-62
Page 29
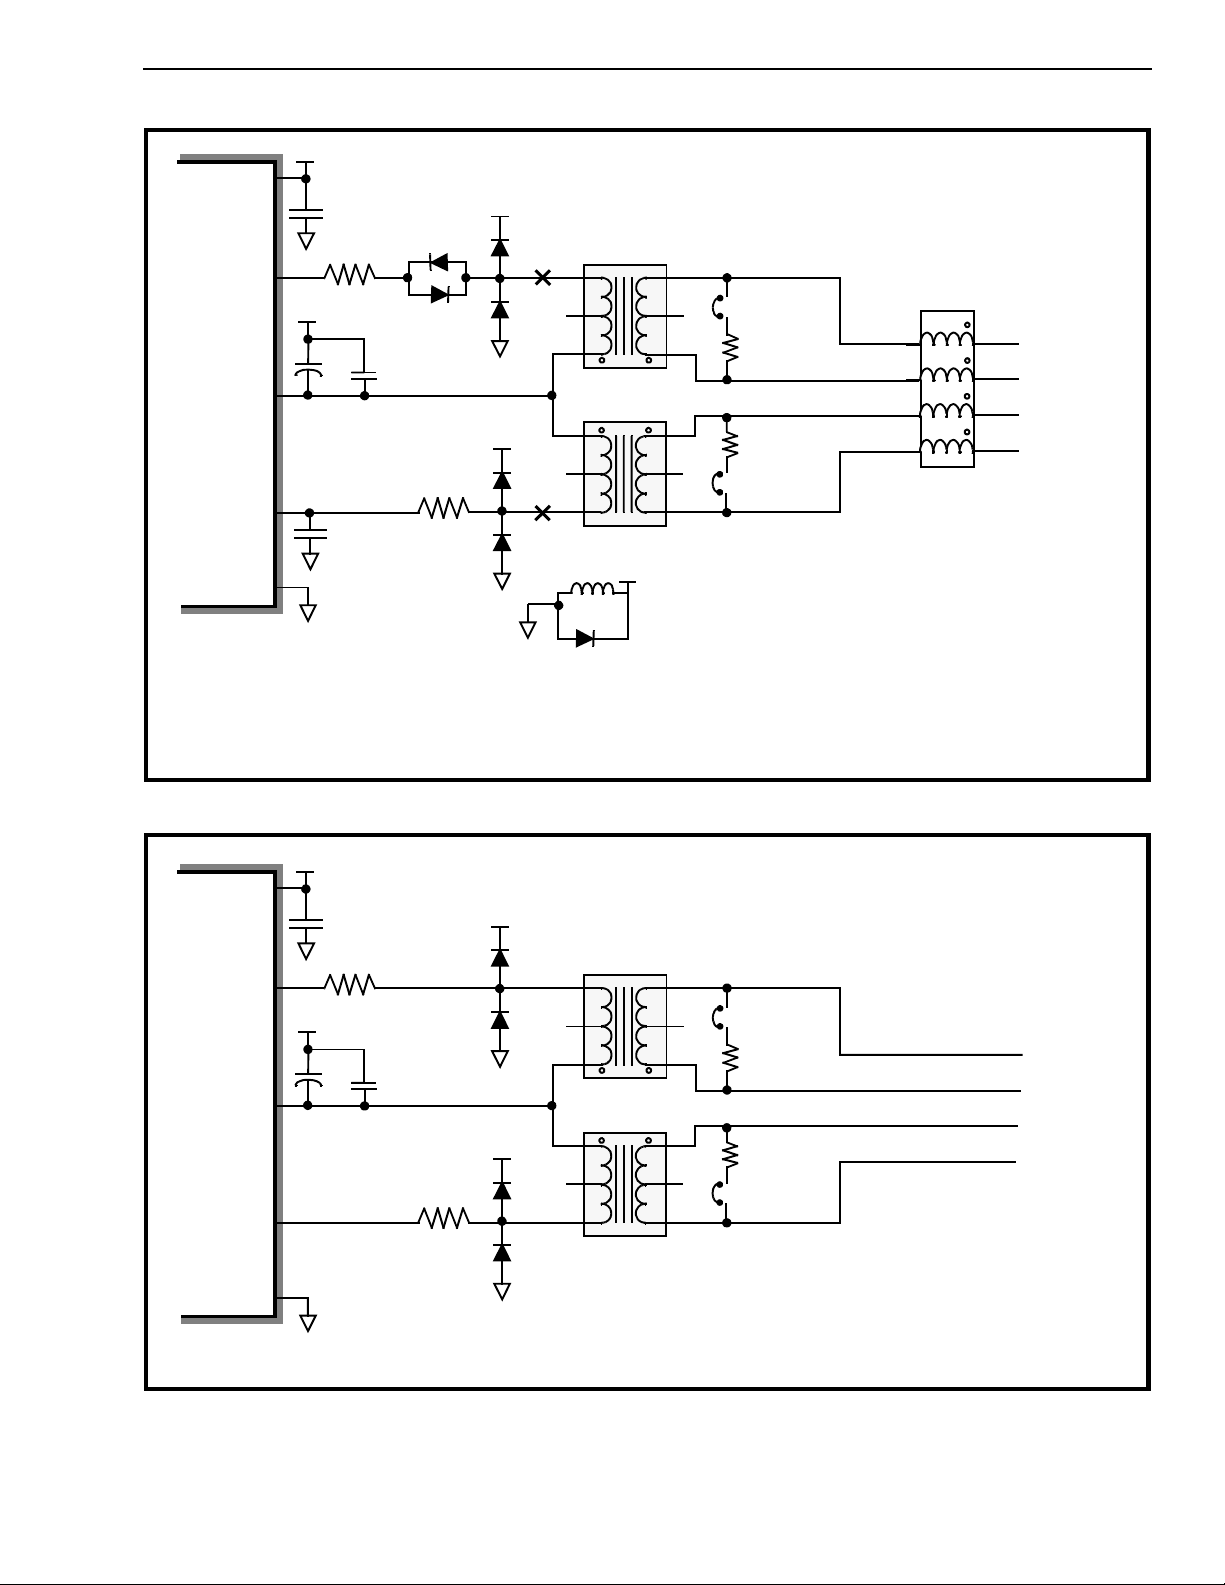
Preliminary Information MT8930C
V
DD
V
MT8930C
LTx
V
LRx
V
DD
Bias
SS
C1
R1
V
DD
+
C2
C3
C4
V
DD
D5
D6
R2
D1
D2
V
DD
D3
D4
T1
5
K1
4
3
T2
3
4
5
K1
K1
6
1
2
2
1
6
R3
R4
L1
Tx+
Tx-
Rx-
Rx+
Parts Li st:
C1, 3 = 0.1µF Ceramic
V
DD
C2 = 10µF Tantalum
C4 = 22pF
D1-4 = IN914
D5, 6 = IN270 Germanium
D7 = IN4003
D7
K1 = 2 Form A or C Relay
(eg., Aromat TQ2E-5V)
L1 = see circuit description
R1 = 1Ω 1%
R2 = 3k01 1%
R3, 4 = 100Ω 1%
T1, 2 = see circuit description
MT8930C
V
LTx
V
LRx
V
DD
Bias
SS
Figure 20 - ETS 300-012 NT & TE Line Interface
V
DD
V
C1
R1
V
DD
+
C2
C3
R2
DD
D1
D2
V
DD
D3
T1
R3
T2
R4
Tx+
Tx-
Rx-
Rx+
Parts List:
D4
C1, 3 = 0 . 1 µF Ceramic
C2 = 10µF Tan talum
D1-4 = IN914
R1 = see circuit description
R2 = 2k to 4k
R3, 4 = 1 0 0 Ω
T1, 2 = see circuit description
Figure 21 - Proprietary NT & TE Line Interfa ce
9-63
Page 30
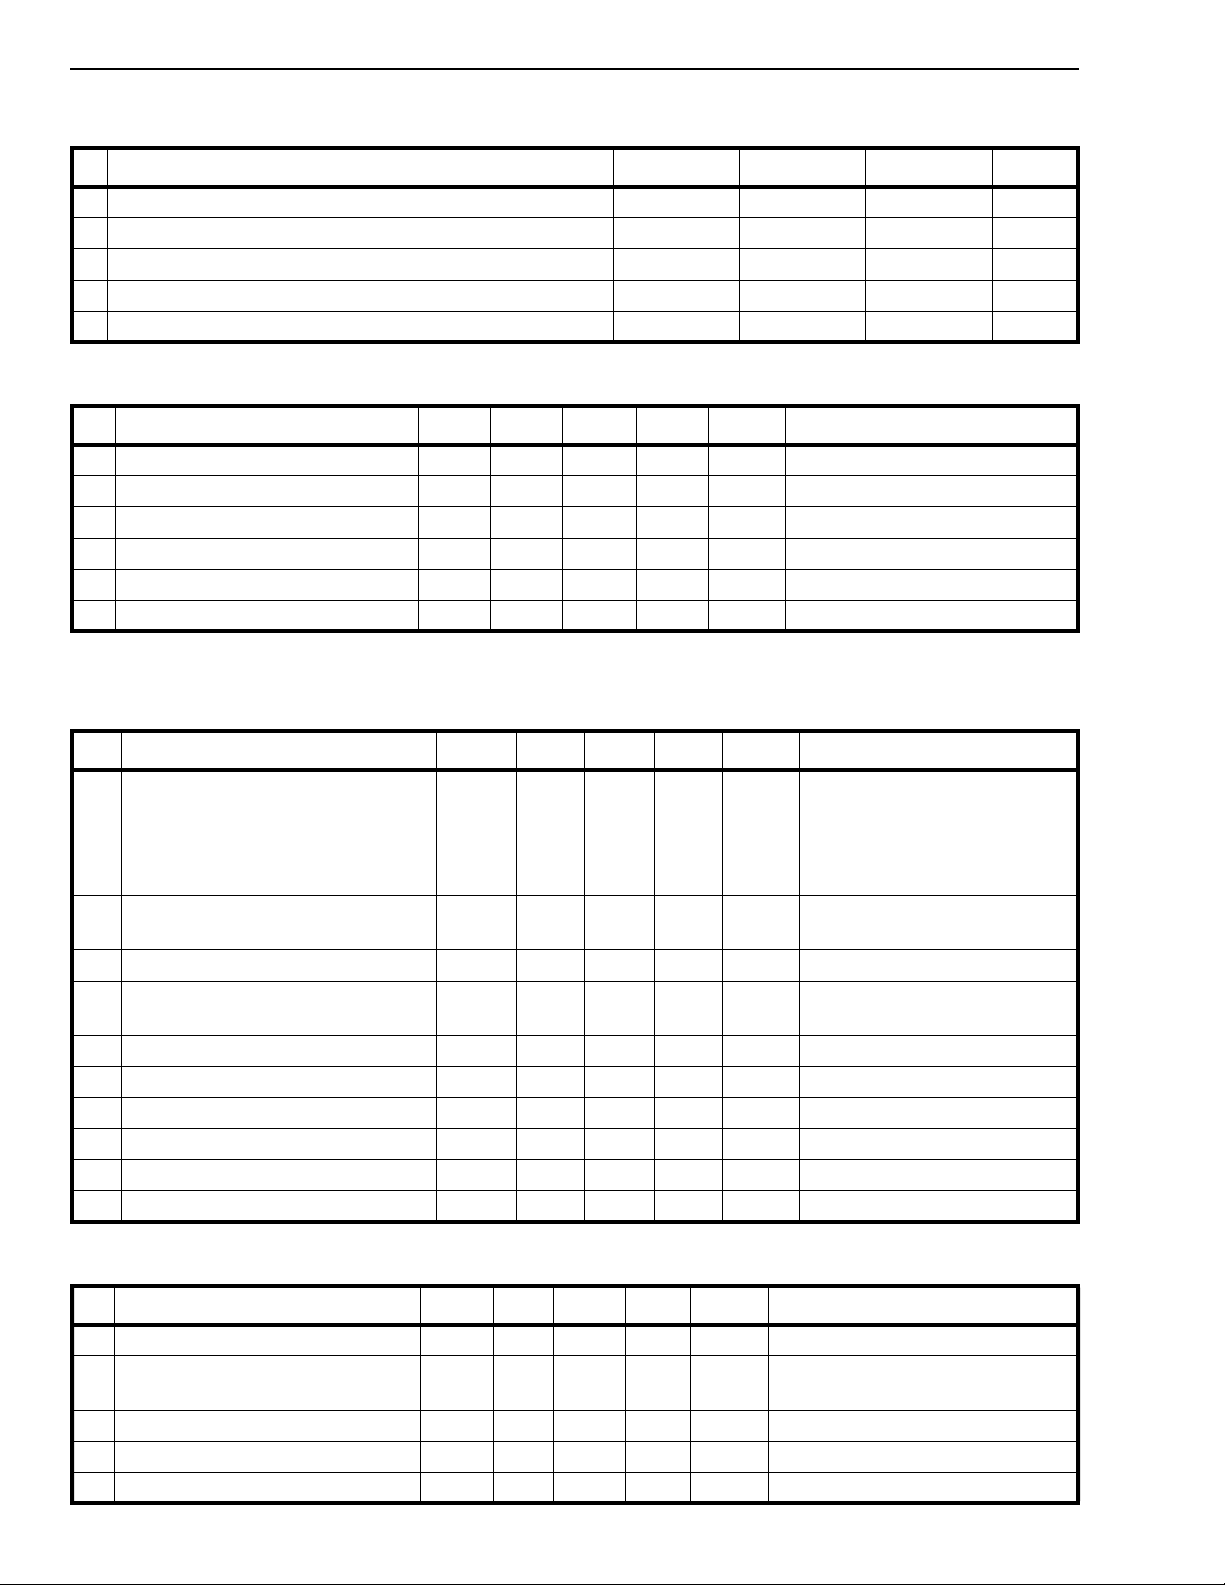
MT8930C Preliminary Informatio n
Absolute Maximum Ratings*
Parameters Symbol Min Max Units
1 Supply Voltage V
2 Voltage on any I/O pin V
3 Current on any I/O pin I
4 Storage Temperature T
5 Package Power Dissipation P
* Exceeding these values may cause permanent damage. Func tional operation under these conditions is not implied.
DD
I/O
I/O
ST
D
Recommended Operating Conditions - Voltages are with respect to ground (V
Characteristics Sym Min Typ
1 Supply Voltage V
2 Input High Voltage* V
3 Input Low Voltage* V
4 Load Resistance (LTx) R
5 Load Capacitance (LTx) C
6 Operating Temperature T
‡ Typic a l figures are at 25°C and are for design aid only: not guaranteed and not subject to production testing.
* Except for CK/NT p in. See below.
** Including the transformer DC resistance.
4.75 5.0 5.25 V
DD
2.4 V
IH
IL
L
L
OP
0 0.4 V For 400mV noise margin
-40 85 °C
DC Electrical Characteristics - Voltages are with respect to ground (V
‡
Max Units Test Conditions
DD
250** Ω With reference to V
32 pF With reference to V
) unless otherwise stated
SS
-0.3 7.0 V
-0.3 VDD + 0.3 V
-65 150 °C
) unless otherwise stated
SS
V For 400mV noise margin
Characteristics Sym Min Typ‡Max Units Test Conditions
20 mA
1000 mW
Bias
Bias
1 Supply Current
NT Activated
NT Deactivated
TE Activated
TE Deactivated
2 Input High Voltage except for pin
I
DDNA
I
DDND
I
DDTA
I
DDTD
V
IH
2.0 V Digital inputs
14
8
16
10
20
11
25
14
mA
mA
mA
mA
Outputs loaded
Outputs unloaded
Outputs loaded
Outputs unloaded
CK/NT
3 Input High Voltage for pin CK/NT V
4 Input Low Voltage except for pin
IH
V
IL
4 V Digital input
0.8 V Digital inputs
CK/NT
5 Input Low Voltage for pin CK/NT V
6 Output High Current I
7 Output Low Current I
8 Input Leakage (except pin 8) I
OH
OL
IL
10 15 mA VOH=2.4V digital outputs
5 7.5 mA VOL=0.4V digital outputs
iI
1 V Digital input
10 µAVIN = V
9 Input Current for pin 8 25 µAVIN = V
10 Output Leakage High Imped. I
‡ Typic a l figures are at 25°C and are for design aid only: not guaranteed and not subject to production testing.
OZ
AC Electrical Characteristics - Voltages are with respect to ground (V
10 µAV
) unless otherwise stated
SS
OUT
Characteristics Sym Min Typ‡Max Units Test Conditions
1 Input Voltage (LRx) V
2 Input Current (LRx) I
IN
IN
1.5 V Peak with Ref. to V
70 µAVI=1.5Vp Ref. V
@ f=0 - 100 kHz
3 Output Voltage (LTx) V
4 Output Current (LTx) I
5 Input Impedance (LRx) Z
‡ Typic a l figures are at 25°C and are for design aid only: not guaranteed and not subject to production testing.
9-64
O
O
20 kΩ f = 100 kHz
IN
1.5 V Ref. V
7.5 mA VO=1.5Vp Ref. V
SS
SS
= V
SS
, RL=250Ω
Bias
to V
to V
to V
DD
DD
DD
Bias
Bias
, RL=250Ω
Bias
Page 31
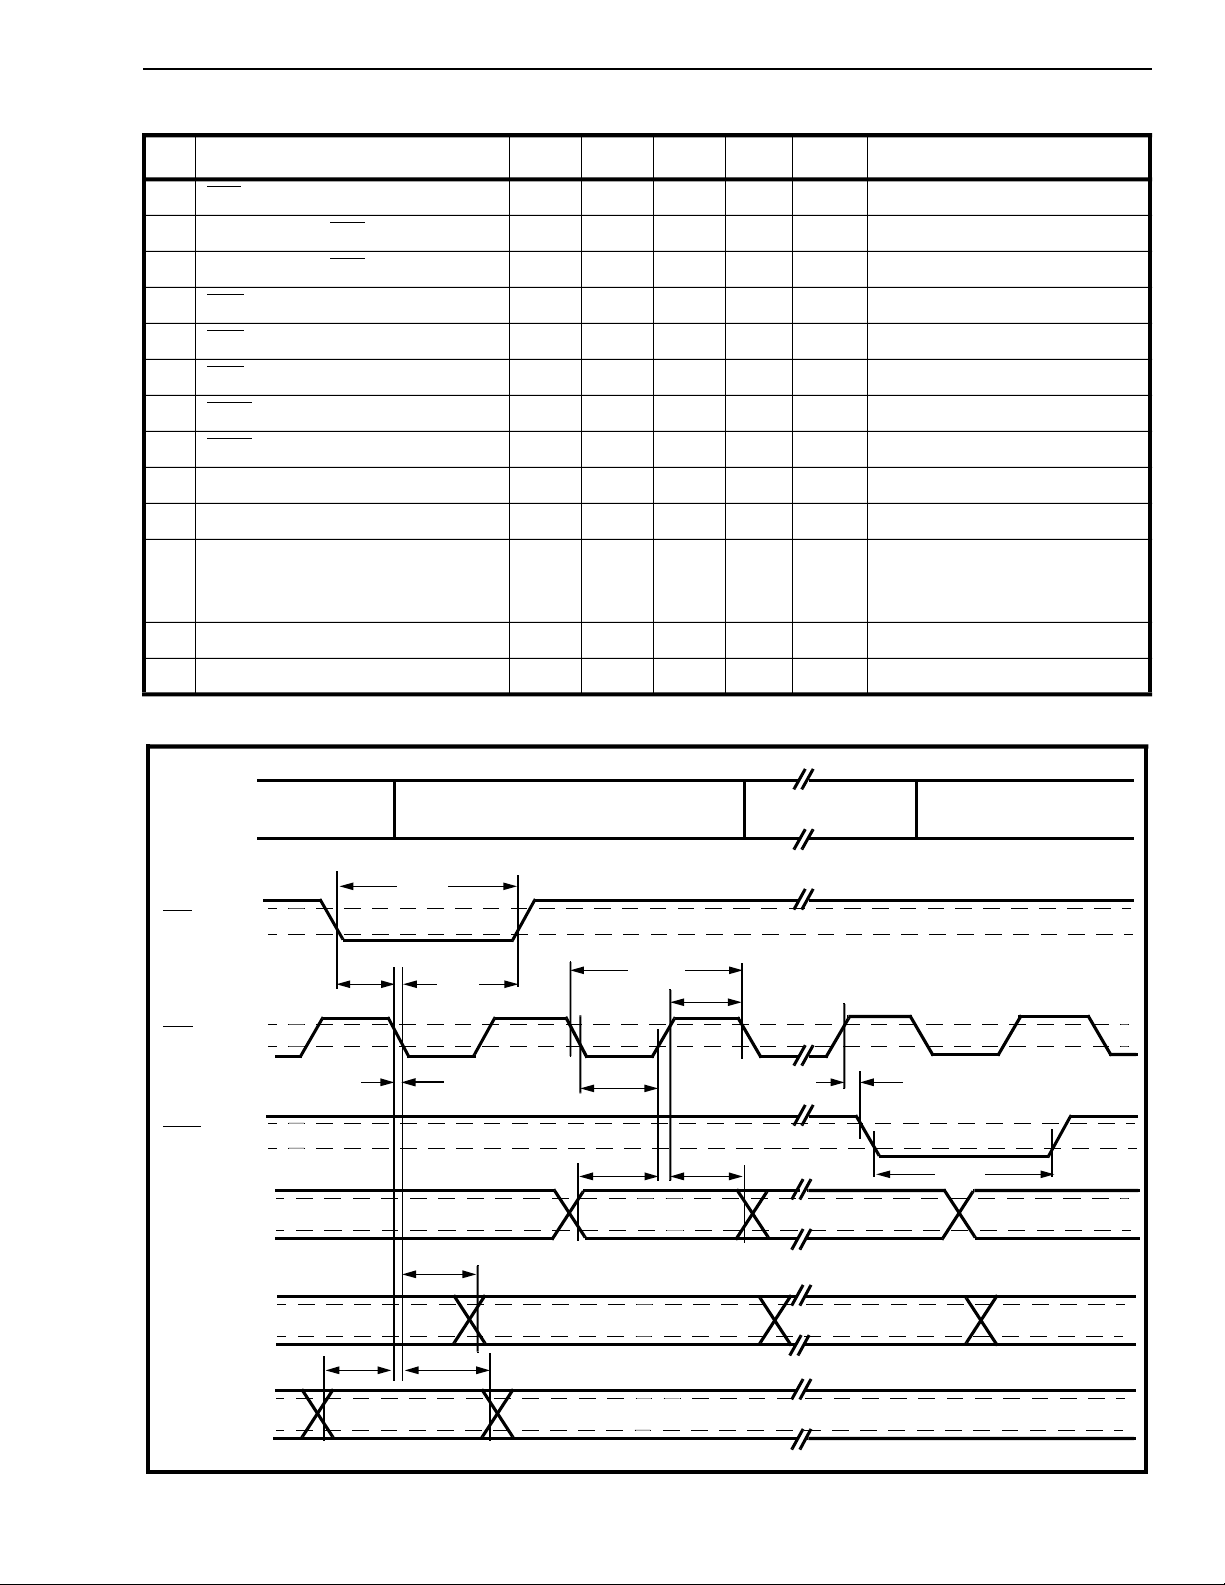
Preliminary Information MT8930C
AC Electrical Characteristics† - ST-BUS Timing NT Mode (Ref. Figure 22)
Characteristics Sym Min Typ‡Max Units Test Conditions
1F0b
2 Frame pulse (F0b
3 Frame pulse (F0b
4 C4b
5 C4b
6 C4b
7 F0od
8 F0od
9 Serial input set-up time t
10 Serial input hold time t
11 Serial output delay t
input pulse width t
) set-up time t
) hold time t
input clock period t
pulse width High or Low t
transition time t
delay t
pulse width t
FPW
FPS
FPH
P4o
C4W
C4T
DFD
DFW
SIS
SIH
SOD
122 244 ns
35 ns
50 ns
244 ns
122 ns
20 ns
20 87 ns 40 pF Load
244 ns
70 ns
0ns
160
320
nsns50 pF load
50 pF load (HDLC connected
to ST-BUS)
12 HALF input setup time t
13 HALF input hold time t
† Timing is over recommended temperature & power supply voltages
‡ Typic a l figures are at 25°C and are for design aid only: not guaranteed and not subject to production test ing.
HAS
HAH
0ns
200 ns
F0b
C4b
F0od
DSTi
DSTo
ST-BUS Bit Cell
t
FPW
V
IH
V
IL
t
t
t
C4W
SIS
P4o
t
C4W
t
SIH
t
DFD
t
DFW
t
FPS
V
IH
V
IL
V
OH
V
OL
V
IH
V
IL
V
OH
V
OL
t
HAS
t
C4T
t
SOD
t
HAH
t
FPH
HALF
V
IH
V
IL
Figure 22 - ST-BUS Timing NT Mode
9-65
Page 32
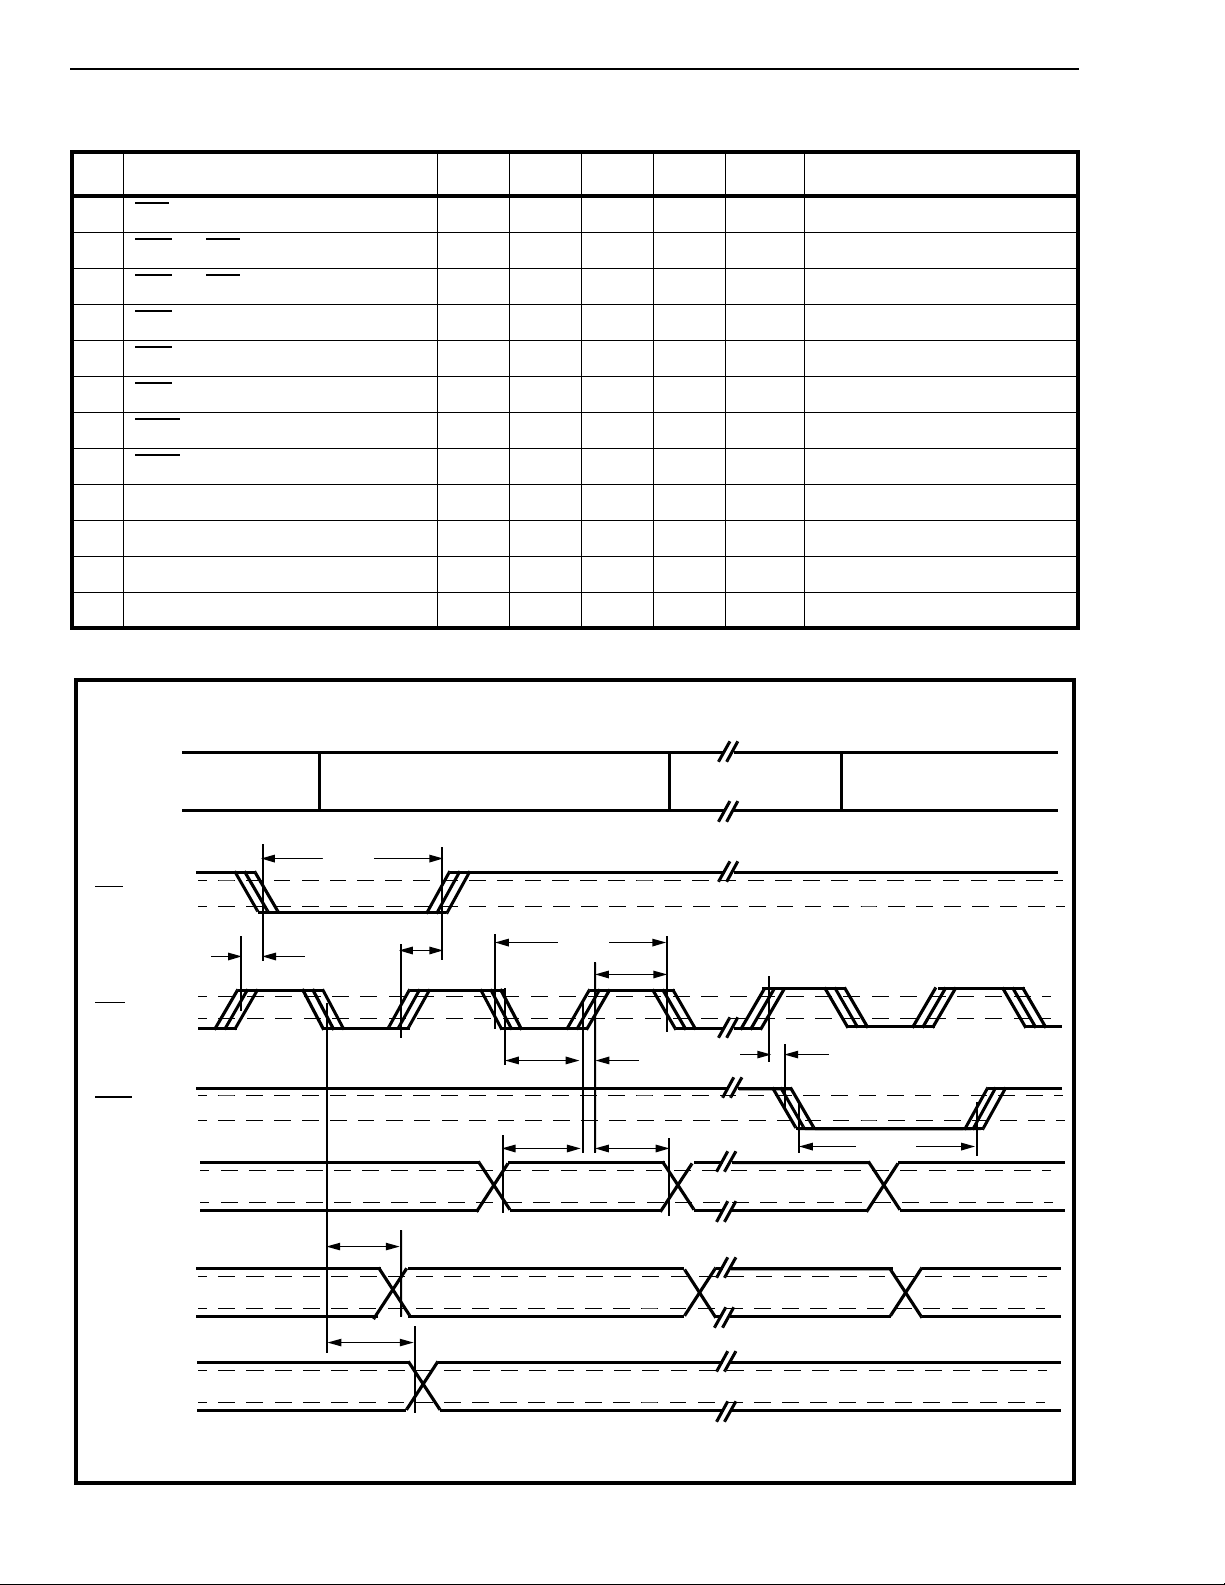
MT8930C Preliminary Informatio n
AC Electrical Characteristics† - ST-BUS Timing TE Mode (Ref. Figure 23)
Characteristics Sym Min Typ‡Max Units Test Conditions
1F0b
2 C4b
3 C4b
4 C4b
5 C4b
6 C4b
7 F0od
8 F0od
9 Serial input setup time t
10 Serial input hold time t
11 Serial output delay t
12 HALF output Delay t
† Timing is over recommended temperature & power supply voltages
‡ Typic a l figures are at 25°C and are for design aid only: not guaranteed and not subject to production testing.
output pulse width t
to (F0b) delay t
to (F0b) hold time t
output clock period t
pulse width High or Low t
transition time t
delay t
pulse width t
ST-BUS Bit Cell
FPW
CFD
CFH
P4o
C4W
C4T
DFD
DFW
SIS
SIH
SOD
HAD
244 ns 50 pF load
10 50 ns 50 pF load
10 50 ns 50 pF load
244 ns 50 pF load
110 122 ns 50 pF load (activated state)
20 ns 50 pF load
10 50 ns
220 244 ns
150 ns
0ns
125 ns 50 pF load
150 ns 50 pF load
F0b
C4b
F0od
DSTi
DSTo
HALF
t
FPW
V
OH
V
OL
t
t
SOD
t
HAD
CFH
t
CFD
V
OH
V
OL
V
OH
V
OL
V
IH
V
IL
V
OH
V
OL
V
OH
V
OL
t
t
C4W
SIS
t
P4o
t
C4W
t
t
C4T
t
SIH
DFD
t
DFW
9-66
Figure 23 - ST-BUS Timing TE Mode
Page 33
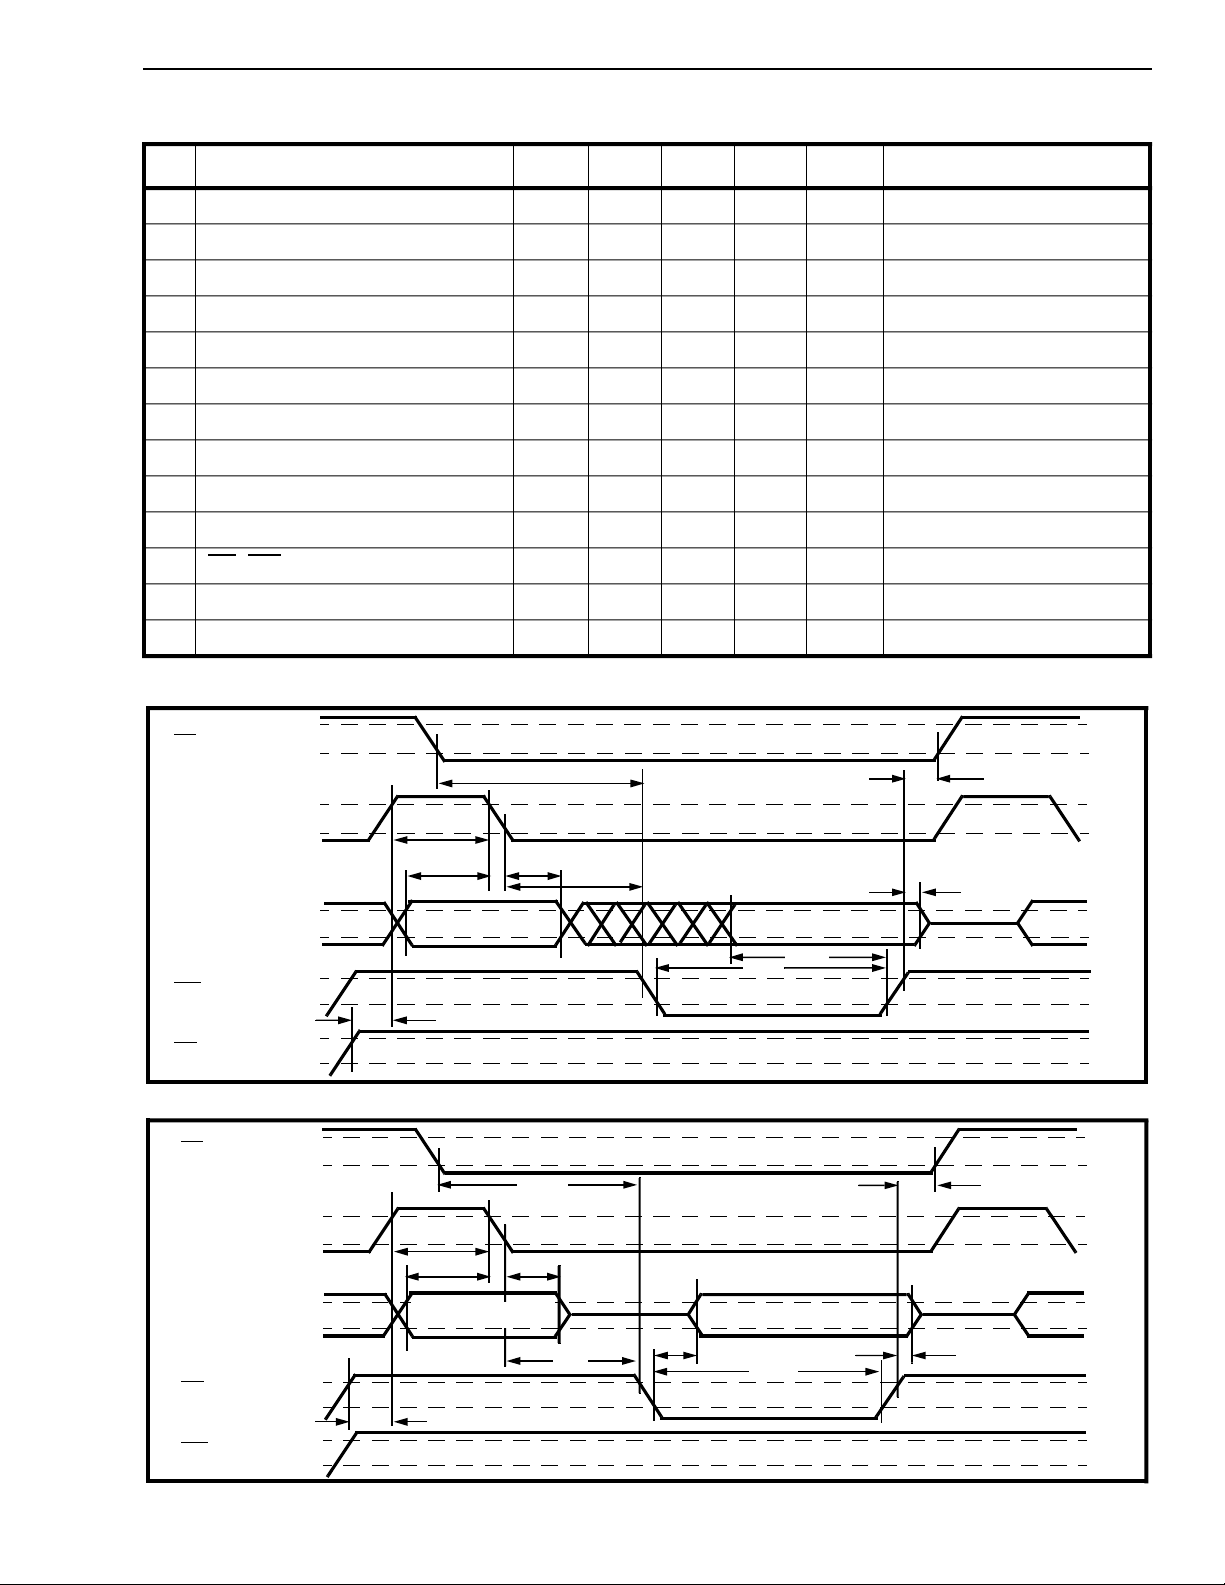
Preliminary Information MT8930C
AC Electrical Characteristics† - Intel Bus Interface Timing (Ref. Figure 24 & 25)
Characteristics Sym Min Typ
‡
Max Units Test Conditions
1 Chip select setup time t
2 Chip select hold time t
3 Address Latch pulse width t
4 Address setup time t
5 Address hold time t
6 Data setup time - Write t
7 Data hold time - Write t
8 Data output delay - Read t
9 Data hold time - Read t
10 Write pulse width t
11 RD
, WR delay t
12 Read pulse width t
13 Read setup time t
CSS
CSH
ALW
ADS
ADH
DWS
DHW
DOD
DHR
WPW
RWD
RPW
RDS
10 ns
25 ns
50 ns
20 ns
20 ns
35 ns
20 ns
240 ns 50 pF load
25 90 ns 50 pF load
60 ns
60 ns
240 ns
20 ns
† Timing is over recommended temperature & power supply voltages
‡ Typic a l figures are at 25°C and are for design aid only: not guaranteed and not subject to production test ing.
V
IH
CS
ALE
V
IL
t
CSS
V
IH
V
IL
t
ALW
t
ADS
t
ADH
t
RWD
t
CSH
t
DHW
AD0-7
WR
RD
CS
ALE
AD0-7
RD
WR
V
IH
V
IL
V
IH
V
IL
V
IH
V
IL
t
RDS
Address Data in
t
DWS
t
WPW
Figure 24 - Intel Bus Interface Timing (Write Cycle)
V
IH
V
IL
V
IH
V
IL
V
I/OH
V
I/OL
V
IH
V
IL
V
IH
V
IL
t
RDS
t
ALW
t
ADS
Address
t
t
ADH
CSS
t
RWD
t
DOD
Data out
t
RPW
t
CSH
t
DHR
Figure 25 - Intel Bus Interface Timing (Read Cycle)
9-67
Page 34
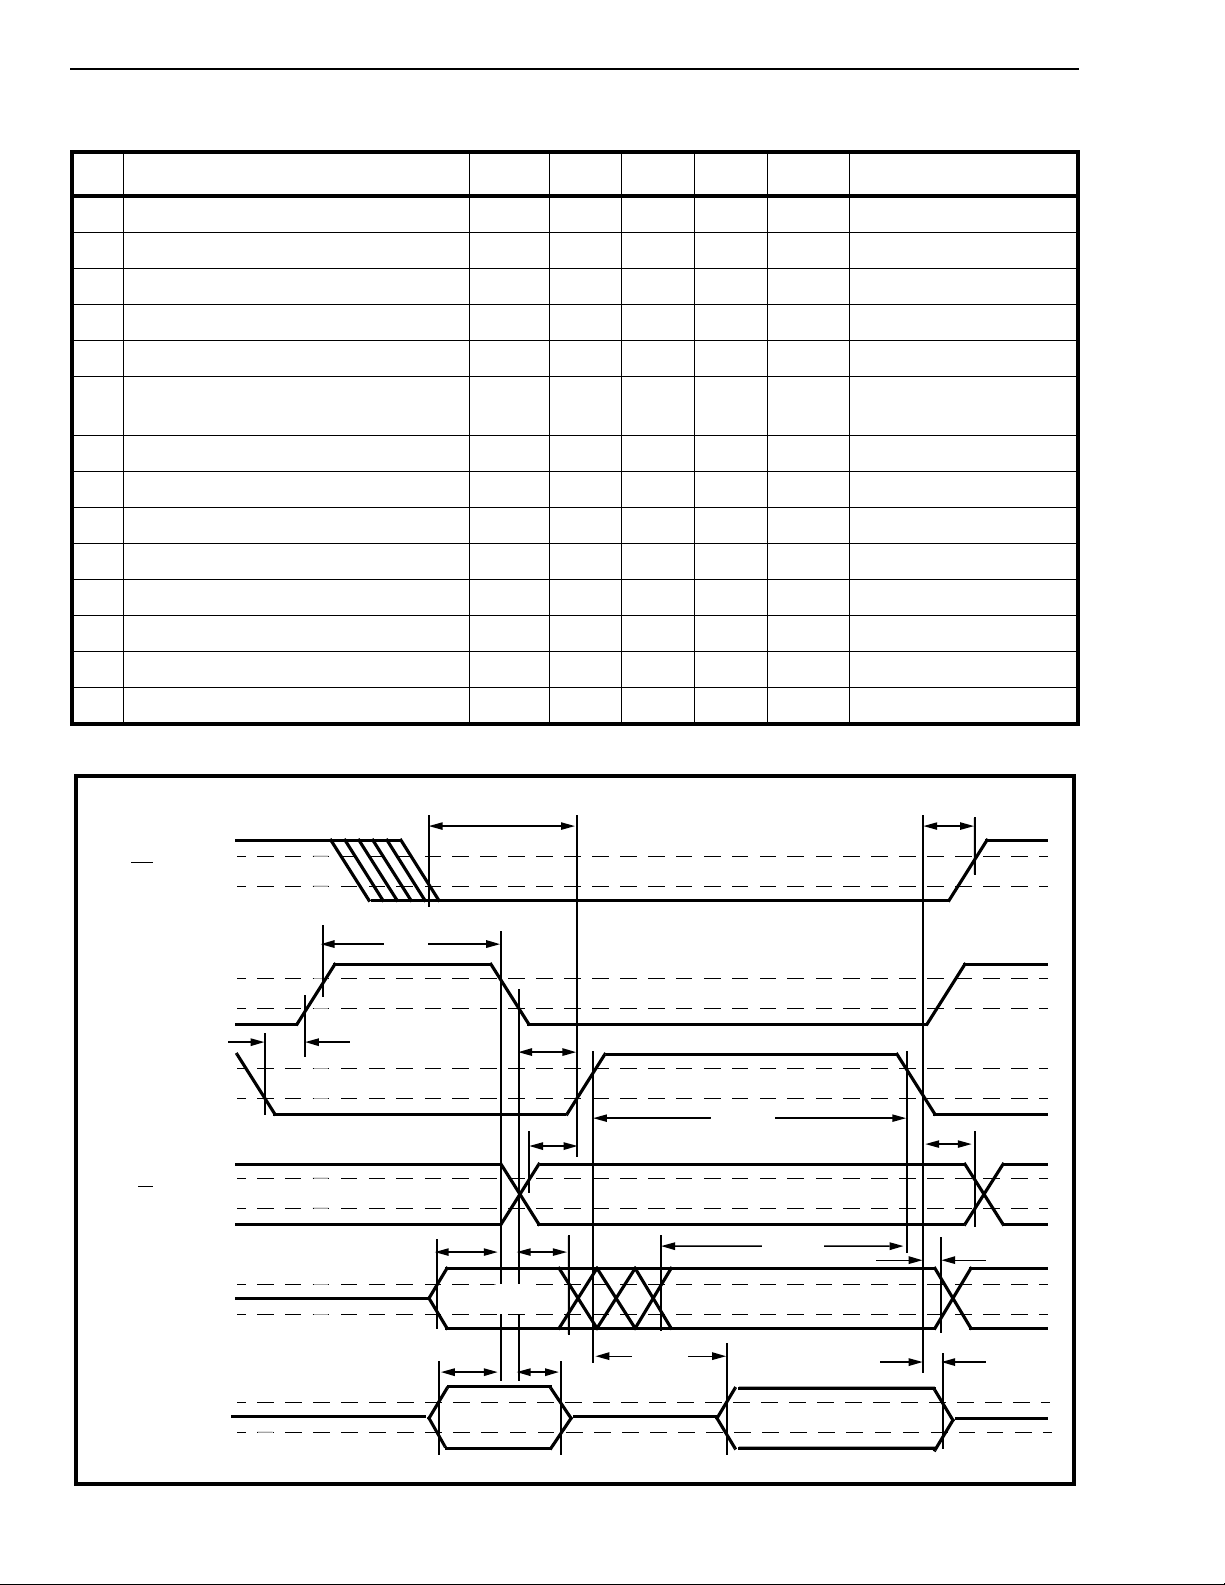
MT8930C Preliminary Informatio n
AC Electrical Characteristics† - Motorola Bus Interface Timing (Ref. Figure 26)
Characteristics Sym Min Typ
‡
Max Units Test Conditions
1 Chip select setup ti me t
2 Chip select hol d time t
3 Address strobe pulse width t
4 Data strobe setup time t
5 Data strobe hold t
6 Data strobe pulse width - Write
CSS
CSH
ASW
DSS
DSH
t
DSW
- Read
7 Read/Write setup time t
8 Read/Write hold time t
9 Address setup time t
10 Address hold time t
11 Data setup time - Write t
12 Data hold time - Write t
13 Data output delay t
14 Data hold time - Read t
† Characteristics are for clocked operation over the ranges of recommended operating temperature and supply voltage.
‡ Typic a l figures are at 25°C and are for design aid only: not guaranteed and not subject to production testing.
RWS
RWH
ADS
ADH
DWS
DHW
DOD
DHR
10 n s
10 n s
50 ns
20 ns
20 ns
100
240
ns
ns
40 ns
10 ns
20 ns
20 n s
35 ns
30 ns
240 ns 50 pF load
25 90 ns 50 pF load
CS
AS
DS
R/W
AD0
-AD7
(Write)
t
CSS
V
IH
V
IL
t
ASW
V
IH
V
IL
t
DSS
V
IH
V
IL
V
IH
V
IL
t
ADS
V
IH
V
IL
t
ADS
t
DSH
t
t
RWS
t
ADH
Address Data Input
t
ADH
t
DOD
DSW
t
DWS
t
t
CSH
RWH
t
t
DHR
DHW
9-68
AD0
-AD7
(Read)
V
I/OH
V
I/OL
Address Data Output
Figure 26 - Motorola Bus Interface Timing
Page 35
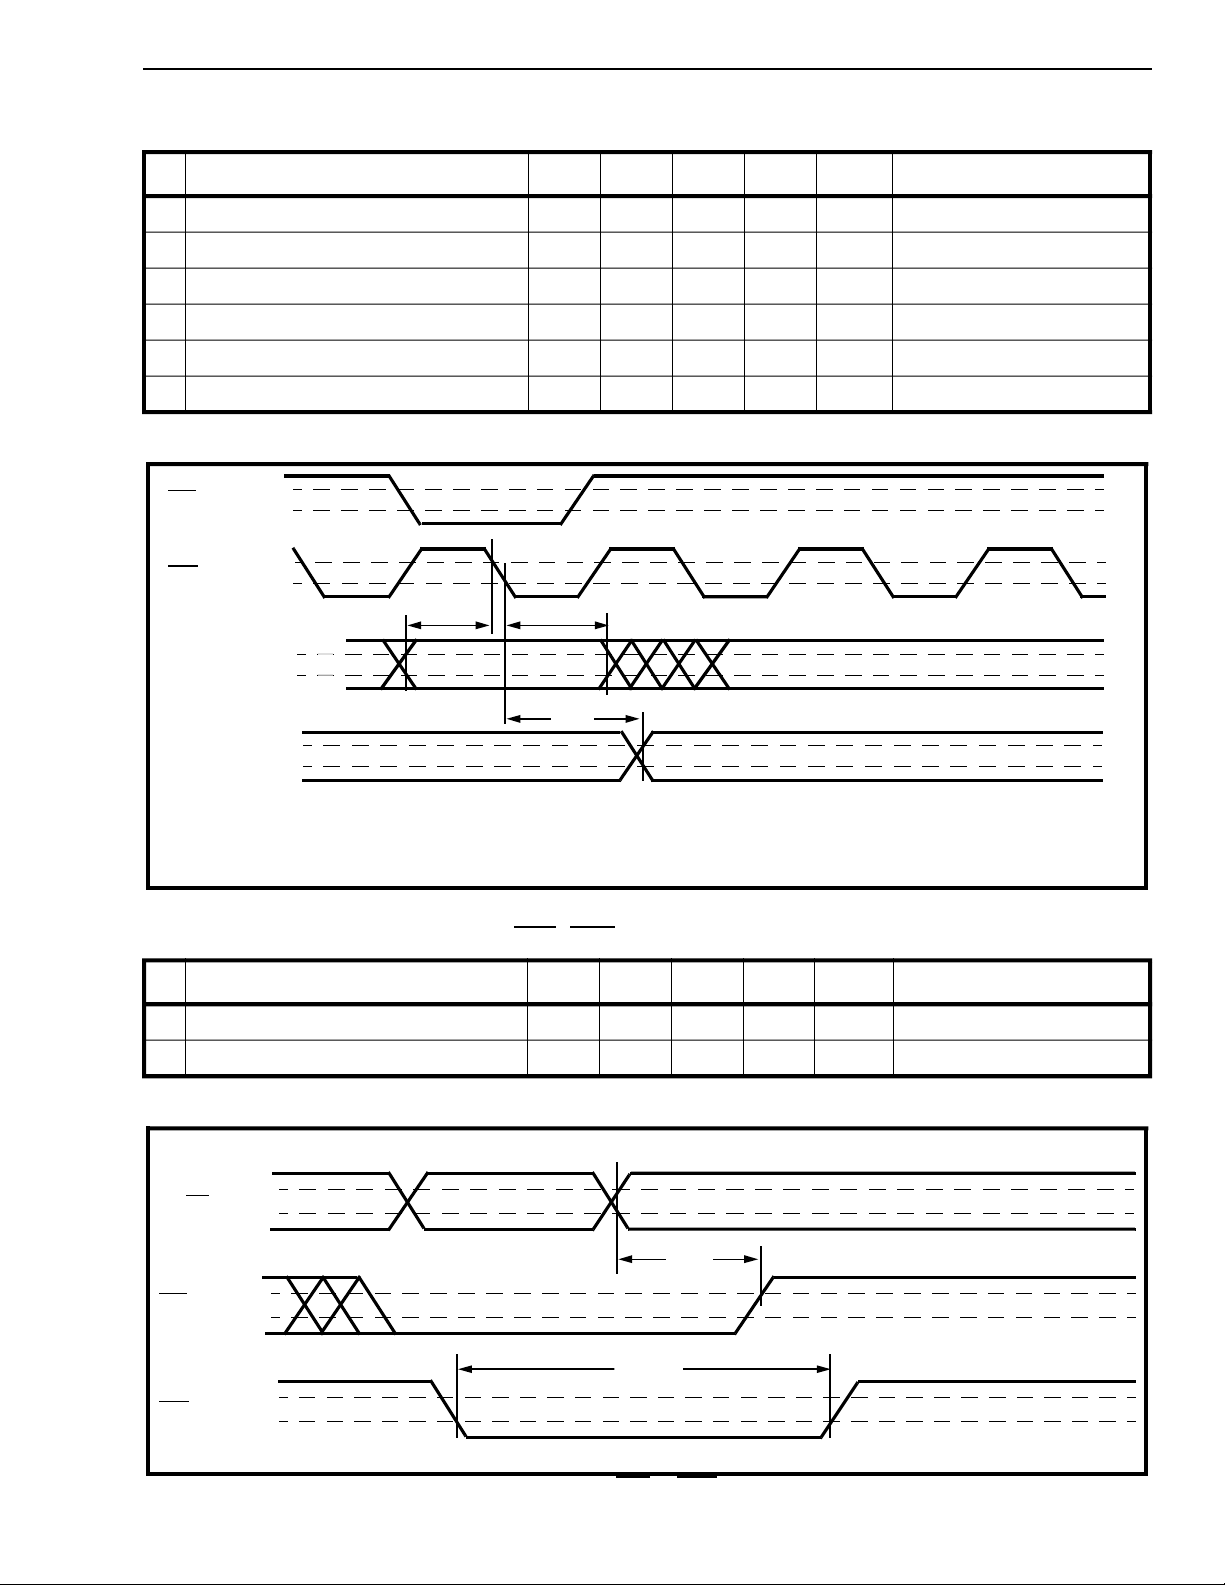
Preliminary Information MT8930C
AC Electrical Characteristics† - Controllerless Mode Timing (Ref. Figure 27)
Characteristics Sym Min Typ
‡
Max Units Test Conditions
1C
2C
3C
4C
5C
6C
† Characteristics are for clocked operation over the ranges of recommended operating temperature and supply voltage.
‡ Typic a l figures are at 25°C and are for design aid only: not guaranteed and not subject to production test ing.
F0b
C4b
Inputs
Outputs
inputs setup time (TE Mode) t
mode
inputs setup time (NT Mode) t
mode
inputs hold time (TE Mode) t
mode
inputs hold time (NT Mode) t
mode
outputs delay (TE Mode) t
mode
outputs delay (NT Mode) t
mode
V
IH
V
IL
V
IH
V
IL
t
CIS
V
IH
V
IL
V
OH
V
OL
t
CIH
CIS
CIS
CIH
CIH
COD
COD
t
COD
120 ns
120 ns
120 ns
120 ns
240 ns 50 pF load
240 ns 50 pF load
Controllerless Inputs include:
MFR (NT Mode)
MCH (TE Mode)
M/S (NT Mode)
AR
DR
Controllerless Outpu ts inclu d e: IS0 & IS1
MFR (TE Mode)
MCH (NT Mode)
M/S (TE Mode)
Figure 27 - Controllerless Mode Timing
AC Electrical Characteristics† - IRQ, Rsti Timing (Ref. Figure 28)
Characteristics Sym Min Typ‡Max Units Test Conditions
1 Interrupt release delay t
2 Reset pulse width t
† Characteristics are for clocked operation over the ranges of recommended operating temperature and supply voltage.
‡ Typic a l figures are at 25°C and are for design aid only: not guaranteed and not subject to production test ing.
V
DS/RD
IRQ
Rsti
IH
V
IL
V
OH
V
OL
V
IH
V
IL
IRD
RSW
1 µs
100 ns
t
IRD
t
RSW
Figure 28 - INT & Rsti Timing
9-69
Page 36
MT8930C Preliminary Informatio n
Notes:
9-70
 Loading...