

Page 1
400 Hot Springs Road, Carson City NV 89706 • (775) 883-0820 • Fax (775) 883-0827 • www.hytek.com • 1
HY5600
TEC Controller
TEC Controllers Laser Diode Drivers Micro-heaters
The HY5600 is a subminiature proportional temperature
controller for thermoelectric coolers (TEC). This device is intended for “cool only” fixed temperature applications where
front panel controls and digital readouts are not required.
The HY5600 operates in conjunction with a thermistor
bridge to precisely measure and regulate the temperature of
a device affixed to a TEC. With proper heat sinking, this device will sink up to 2 Amperes of current and will operate at a
supply voltage up to 12 Volts.
Subminiature Controller for Thermoelectric Coolers
Features:
✦ Proportional/Integral (PI) control
✦ Small size
✦ Drive current to 2 amps
✦ Operation to 12 volts
✦ Control –55°C to ambient
✦ T emperature stability to 0.01°C
✦ Thru-hole or surface-mount packaging
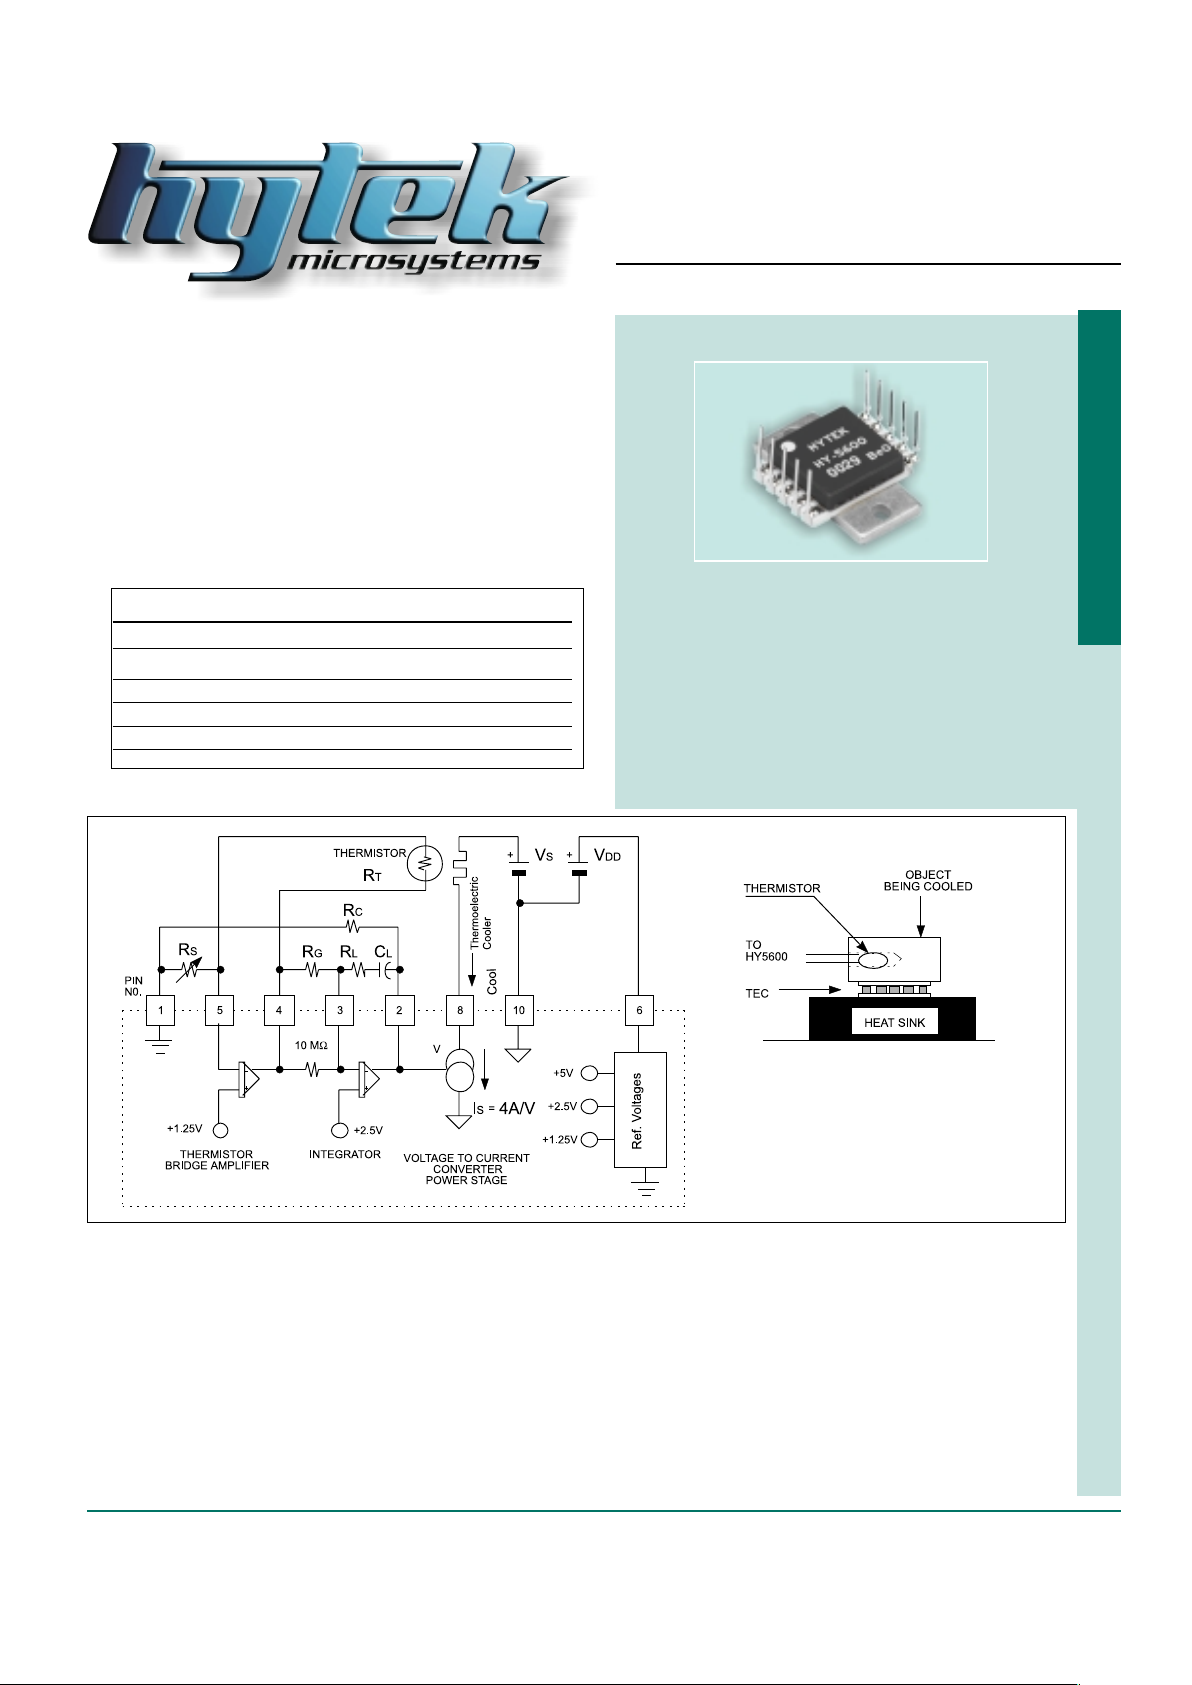
The HY5600 TEC controller consists of a thermistor bridge
amplifier, an integrator/gain stage and a voltage-to-current
converter power drive stage. This is illustrated in the simplified schematic diagram for the HY5600 in Figure 1. The
thermistor bridge precisely measures the temperature of a
device attached to a Thermoelectric Cooler (TEC). The
bridge is balanced when the thermistor value is equal to the
value of the temperature set resistor (Rs). When power is
first applied to the TEC, the temperature of the device attached to the TEC is higher than the desired set tempera-
ture. The resistance of the thermistor is therefore
less than the temperature set resistor. This causes
the current sink to turn on to its maximum programmed value. This maximum current is set with
resistor Rc. The HY5600 will continue to sink maximum current until the programmed temperature is
reached. The current will then decrease to the value
required for maintaining equality between the thermistor and the programming resistor (Rs).
The thermistor should be located as
close to the TEC as possible in order to
avoid thermal lag. In addition, the
thermistor should be attached to the
device being cooled with a good thermally
conductive epoxy or thermal compound.
This material should be electrically
nonconductive.
Theory of operation
Maximum ratings:
Rating Symbol Value Unit
Supply Voltage VDD +20 Volts DC
Supply Voltage 2 ((Voltage on Pin 8) VS +12 Volts DC
Current Sink IS 2.5 Amperes
Maximum Power Dissipation PMAX 6 Watts
Figure 1
MOUNTING THE TERMISTOR
Page 2
2 • 400 Hot Springs Road, Carson City NV 89706 • (775) 883-0820 • Fax (775) 883-0827 • www.hytek.com
HY5600
TEC Controller
Description of the HY5600 pin outs
• Current Limit Resistor, Rc (Pin 1 to Pin 2)
This resistor limits the maximum current that the
HY5600 can sink. This feature will prevent damage to the
TEC during turn-on. If the supply voltage for the TEC
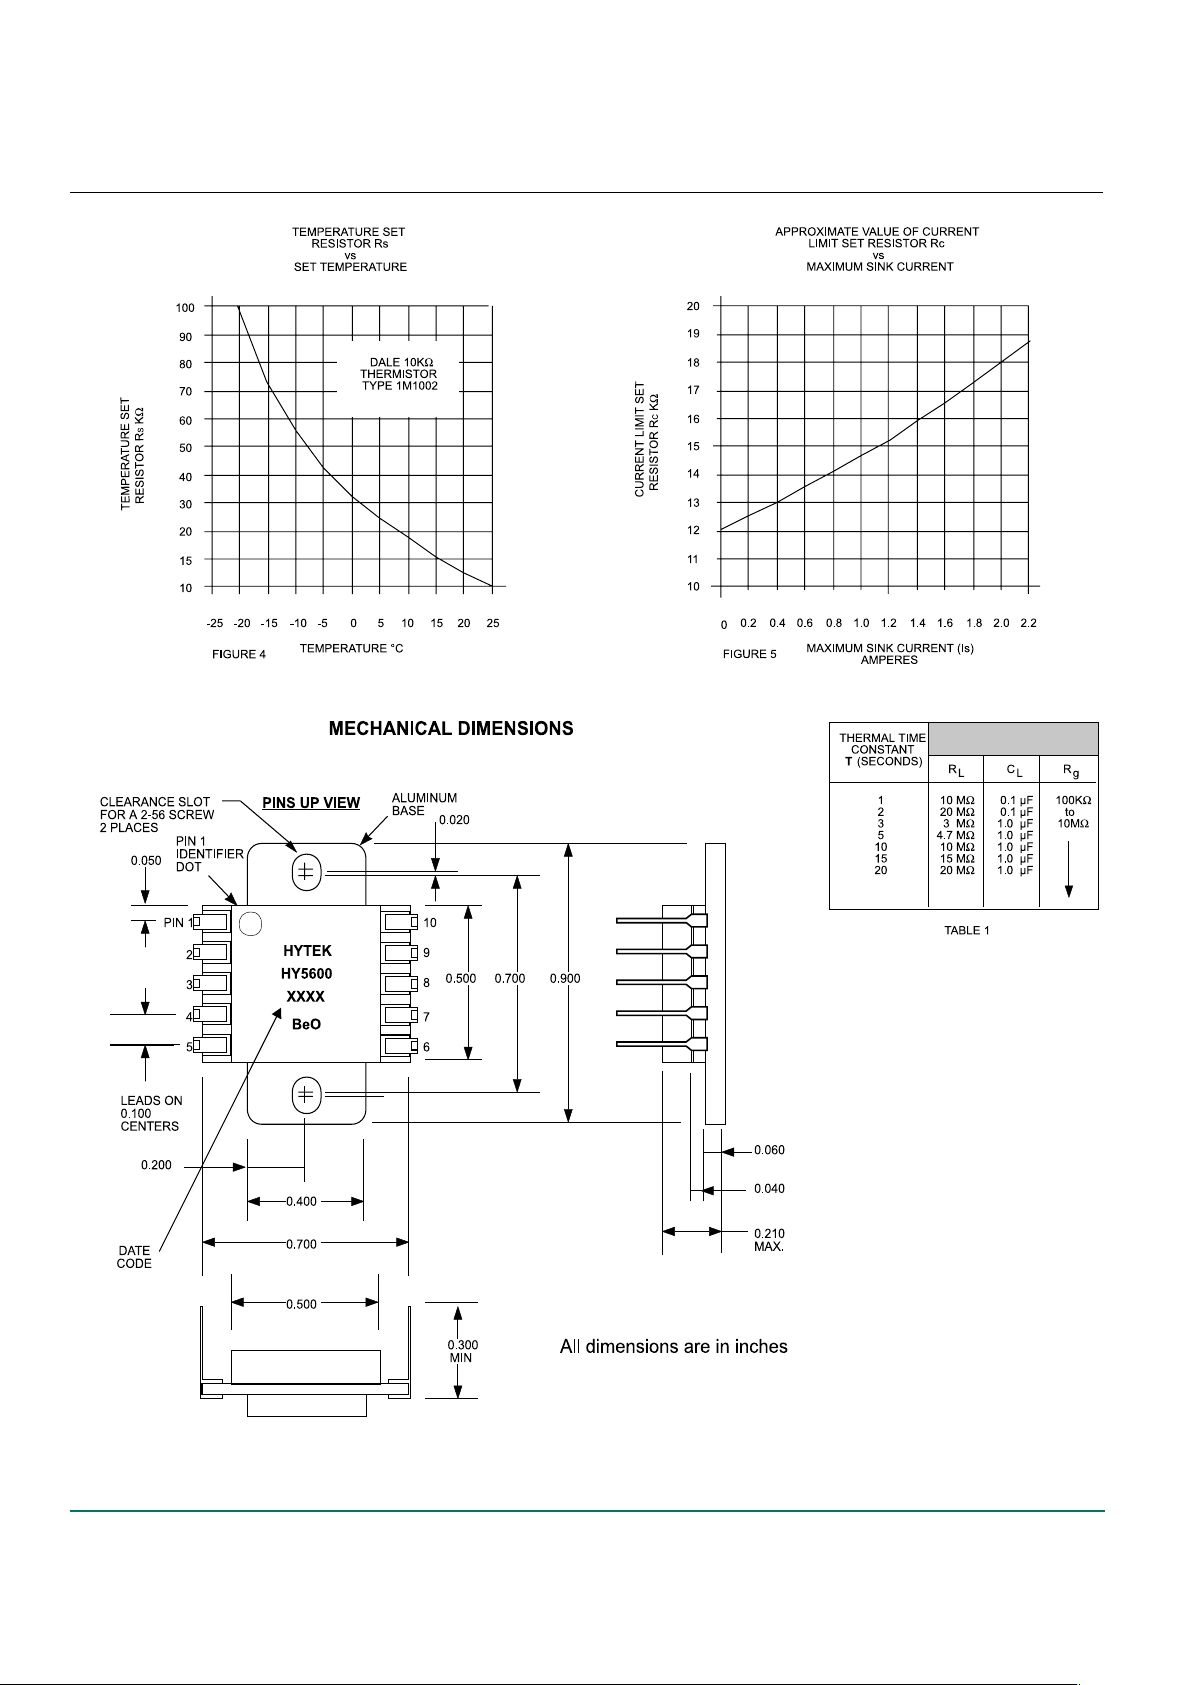
does not exceed the maximum TEC voltage, then this resistor may not be needed. Figure 5 shows the approximate values for Rc required to program a desired turn on
current.
• VDD (Pin 6 to Pin 10 ) +7
≤≤
≤≤
≤
VDD
≤≤
≤≤
≤
+20 Volts
This input supplies the voltage to the internal circuitry of
the HY5600. The maximum current drain at this terminal
is 5mA.
• Thermoelectric Controller, TEC (Pin 8) +3
≤≤
≤≤
≤
V
s
≤≤
≤≤
≤
+12 Volts
Pin 8 connects the TEC to the programmable current
sink in the HY5600. The other lead of the TEC is connected to + Vs. At turn on, the current into Pin 8 is maximum if the temperature of the sensing thermistor is
greater than the programmed set temperature. This maximum turn on current can be limited by Rc. Once the TEC
reaches its set temperature, the current through the TEC
will drop to exactly the value required to maintain the correct set temperature.
Ideally VS is no more than 1.5V higher than the VMAX
of the selected TEC. Setting VS higher than this can
cause excessive heating of the controller.
• Temperature Set Resistor Rs (Pin 1 to Pin 5)
The temperature set resistor for the HY5600 controls the
temperature at which the TEC will operate. When the circuit has stabilized, the resistance of the thermistor will
be equal to that of the set resistor Rs. For example, if a
Dale 10KΩ thermistor is used as the temperature sensing device, a set resistor of approximately 56KΩ will set
an operating temperature of –10°C. A graph of Rs vs. set
temperature is shown in figure 4 when using a Dale
1M1002 thermistor.
• Thermistor, RT (Pin 4 to Pin 5)
The thermistor should be located in close proximity to
the device being cooled. It should be in good thermal
contact with this device to avoid stability problems.
The HY5600 has been designed for a negative temperature coefficient thermistor . A thermistor with a positive temperature coefficient can also be used if the
position of the temperature set resistor and temperature
sensing resistor is changed.
• Gain Set Resistor, RG (Pin 3 to Pin 4)
The ratio of the gain set resistor RG to RL controls the response time of the servo loop. A ratio that is too large
can cause slow response and a ratio that is too small
can cause loop instability . A 1OMΩ resistor, which is in
parallel with RG is internal to the HY5600. In many
cases, an external resistor (RG) is not required.
• Loop Stability Network, RL and
C
L
(Pin 2 to Pin 3)
The RC time constant of these two components is a first
approximation of the thermal time constant of the servo
loop. The thermal time constant of the combination of the
device being cooled, the thermistor, and the TEC can be
approximated by applying constant power to the TEC
and measuring the length of time it takes to reach 66%
of its final temperature.
For example, if the thermal time constant was ob-
served to be 5 seconds, then a 1µF capacitor and a
4.7MΩ could be chosen as the loop stabilizing components. Typical values for loop compensation components
are shown in T able 1.
Note: The values of RG, RL and CL are generally selected
by experiment. CL should be a low leakage
nonpolarized capacitor.
Page 3
400 Hot Springs Road, Carson City NV 89706 • (775) 883-0820 • Fax (775) 883-0827 • www.hytek.com • 3
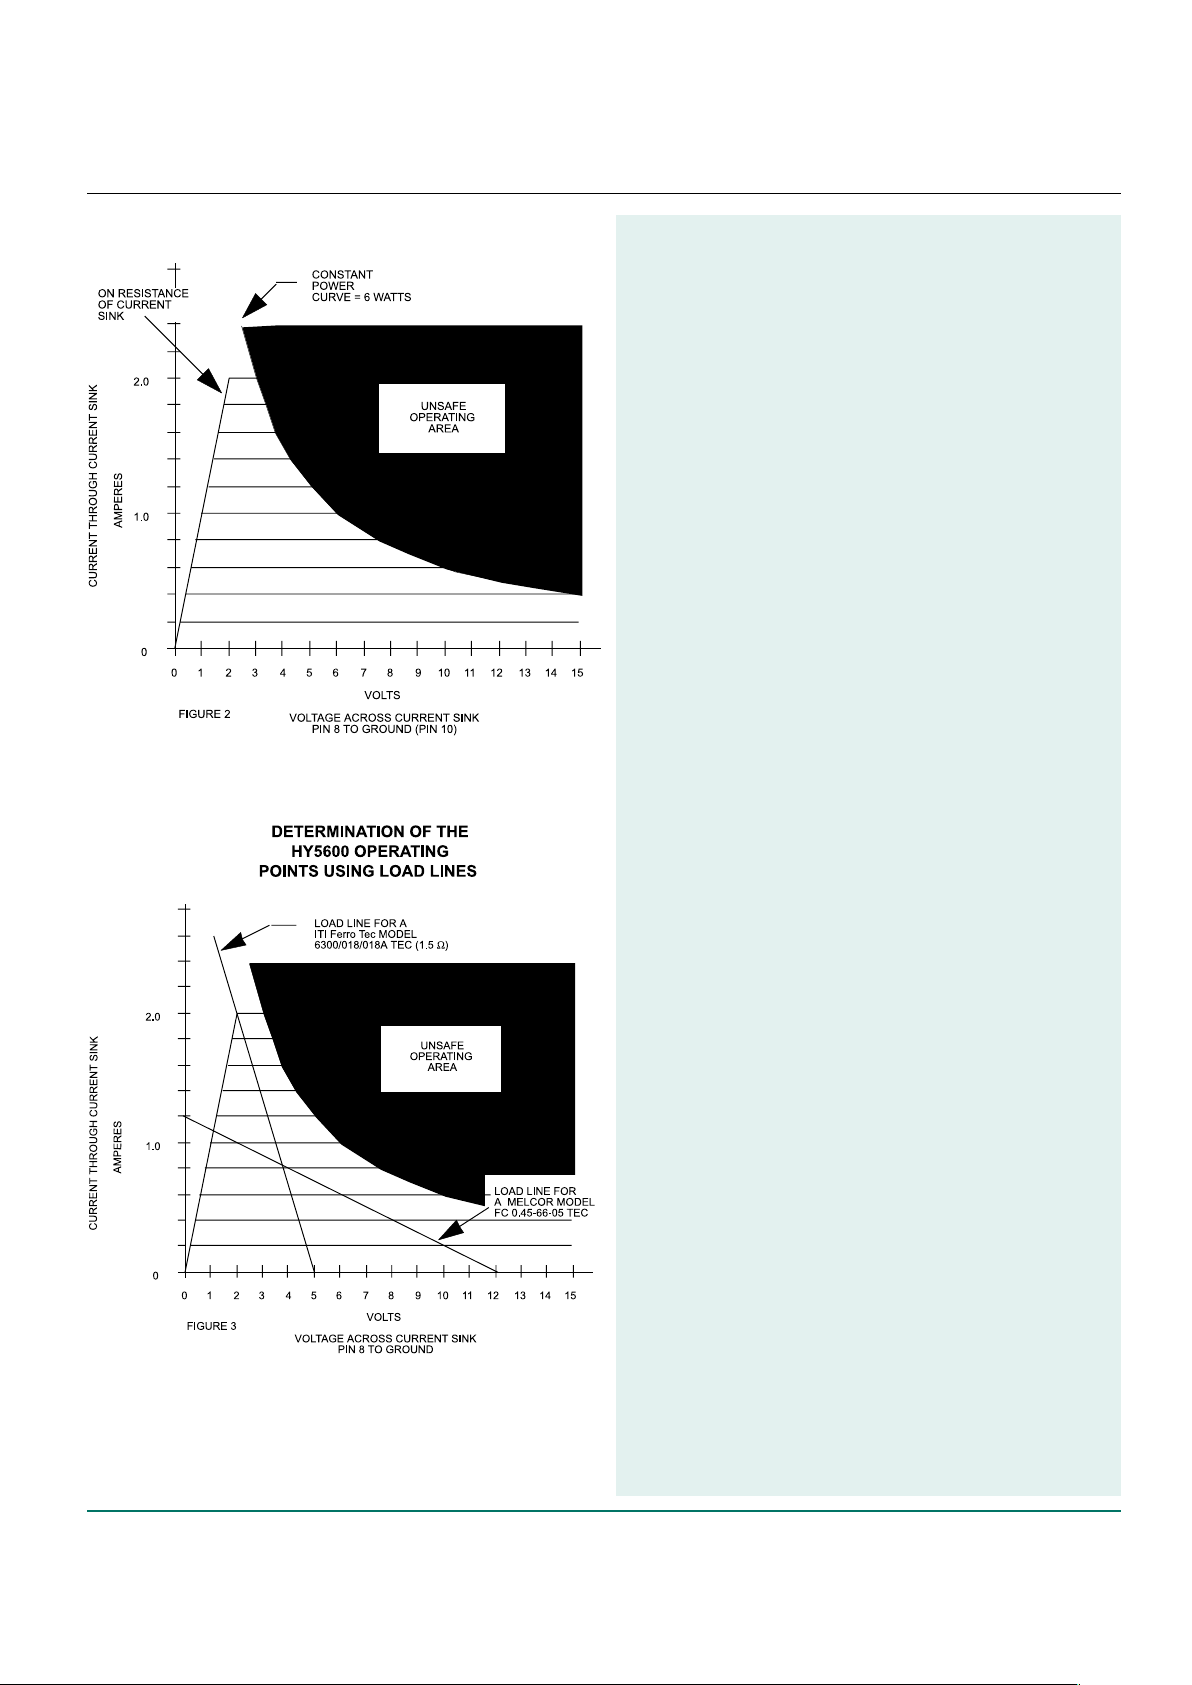
Figure 2 illustrates the characteristics of the
HY5600 current sink. It also illustrates the unsafe
operating area where the power dissipated in the
device exceeds the maximum 6 Watt rating for
this device.
Note that the resistance of the current switch is
approximately one ohm when the current switch is
saturated.
Figure 3 illustrates the locus of operating
current and voltage for two different TECs.
Example 1:
A supply voltage of 5 Volts was chosen for use
with the ITI Ferro T ek Model 6300/018/018A
TEC. This device is rated for a maximum current
of 1.8 Amperes at a maximum allowable voltage
of 2.7 Volts. This is a load resistance of
approximately 1.5 ohms. The intersection of the
1.5 ohm load line and the HY5600 current
source characteristics defines the locus of
operation voltage and current for both the
HY5600 and the TEC. In this application the
current was limited to 1.8 Amperes by proper
selection of Rc.
Example 2:
A supply voltage of 12 Volts was chosen for the
Melcor FC 0.45-66-05 TEC. This device has a
maximum rated voltage of 7.98 Volts at a current
of 0.8 Amperes. A load line for this device is
also shown on the plot.
Note that the power dissipated in the HY5600
never exceeds the 6 Watt maximum power
dissipation.
HY5600
TEC Controller
HY6500 CURRENT SOURCE CHARACTERISTICS
Page 4
4 • 400 Hot Springs Road, Carson City NV 89706 • (775) 883-0820 • Fax (775) 883-0827 • www.hytek.com
HY5600
TEC Controller
NOTES:
1. Make certain the heat sink to
which the HY5600 is mounted is
flat and clean, otherwise the
ceramic substrate may break.
2. Use a thermal compound such
as Dow Corning 340 between
the HY5600 and the heat sink for
good thermal conduction.
Specifications subject to change
without notice.
Figure 6
 Loading...