

Page 1

To all our customers
Regarding the change of names mentioned in the document, such as Hitachi
Electric and Hitachi XX, to Renesas Technology Corp.
The semiconductor operations of Mitsubishi Electric and Hitachi were transferred to Renesas
Technology Corporation on April 1st 2003. These operations include microcomputer, logic, analog
and discrete devices, and memory chips other than DRAMs (flash memory, SRAMs etc.)
Accordingly, although Hitachi, Hitachi, Ltd., Hitachi Semiconductors, and other Hitachi brand
names are mentioned in the document, these names have in fact all been changed to Renesas
Technology Corp. Thank you for your understanding. Except for our corporate trademark, logo and
corporate statement, no changes whatsoever have been made to the contents of the document, and
these changes do not constitute any alteration to the contents of the document itself.
Renesas Technology Home Page: http://www.renesas.com
Renesas Technology Corp.
Customer Support Dept.
April 1, 2003
Page 2

Cautions
Keep safety first in your circuit designs!
1. Renesas Technology Corporation puts the maximum effort into making semiconductor products better and more reliabl e, but
there is always the possibility that trouble may occur with them. Trouble with semicondu ctors may lead to personal injury , fire
or propert y da mage.
Remember to give due consideration to safety when making your circuit designs, with appropriate measu res such as (i)
placement of substitutive, auxiliar y circuits, (ii) use of nonflammable material or (iii) preve n tion ag ain st any malf u nc tio n or
mishap.
Notes regar ding these ma terials
1. These materials are intended as a reference to assist our customers in the selection of the Renesas Technology Corporation
product best suited to the customer's application; they do not convey any license under any intellectual property rights, or any
other rights, belonging to Renesas Technology Corporation or a third party.
2. Renesas Technology Corporation assumes no responsibility for any damage, or infringement of any third-party 's rights,
originating in th e u se of any product data, diagrams, charts, programs, algorithms, or circuit applicatio n examples contained in
these materials.
3. All information contained in these materials, including product data, diag rams, charts, programs and algorithms represents
information on products at the time of publication of these materials, and are subject to change by Renesas Technology
Corporation without notice due to product improvements or other reasons. It is therefore recommended that customers contact
Renesas Technology Corporation or an authorized Renesas Technology Corporation product distributor for the latest product
informati o n be fore purcha si ng a product lis ted herein.
The informa tion described here may contain technic a l inaccuracie s or typograph ical errors.
Renesas Technology Corp oration assumes no responsibility for any damage, liability, or other loss rising from these
inaccuracies or errors.
Please also pay attention to information published by Renesas Technology Corporation by various means, including the
Renesas Technology Corporation Semiconductor home page (http://www.renesas .com).
4. When usi ng any or all of the inf ormation contained in thes e m aterials, inc l ud i ng product data, diagrams, ch ar t s , programs, and
algorithms, please be sure to evaluate all information as a total system before making a final decision on the applicability of
the information and products. Renesas Technology Corporation assumes no responsibi lity for any damage, liability or other
loss resulting from th e information contained herein.
5. Renesas Technology Corporation semiconductors are not designed or manufactured for use in a device or system that is used
under circumstances in which human life is potentially at stake. Please contact Renesas Technology Corporation or an
authorized Renesas Te chnology Corporation product dis tributor when considering the use of a product contained herein for
any specific purposes, such as apparat us or system s for tra nsp or ta tio n, veh icul ar, medica l, aer o space, nucle ar, or unders ea
repeater use.
6. The prior written approval of Renesas Technology Corporation is necessary to reprint or reproduce in whole or in part these
materials.
7. If these products o r technologies are sub ject to the Japanese exp ort contro l restrictions, they must be exported under a l i cense
from the Japanese govern ment and cannot be imported into a country other than the approved destination.
Any diversion or reexport contrary to the export contro l laws and regulations of Japan and/or the country of destination is
prohibited.
8. Please contact Renesas Technology Corporation for further details on these materials or the products contained the rein.
Page 3

HD404829R Series
AS Microcomputer Incorporating a LCD controller/Driver Circuit
ADE-202-057C
Rev.4
Sept. 1999
Description
The HD404829R series incorporates an 8-bit A/D converter (four channels), a Liquid Crystal Display
(LCD) and a serial interface, and has large-current Input/Output (I/O) pins. The series is a 4-bit single-chip
microcomputer best used in the AV equipment such as CD radio cassette tape recorders which require the
LCD display control.
The HD404829R Series, with a 32.768kHz sub-oscillator for clocks, counts up the system clock and a
variety of power modes can reduce power consumption.
The HD4074829 is a ZTATTM microcomputer which incorporates a PROM. System development period
has been dramatically reduced so that the process from debugging to mass production is smooth. (The
PROM programming specifications are the same as those for Type 27256.)
ZTATTM: Zero Turn Around Time ZTAT is a trademark of Hitachi Ltd.
Features
• 1,876-digit × 4-bit RAM
• 44 I/O pins, including 10 high-current pins (15 mA, max.) and 20 pins multiplexed with LCD segment
pins
• Four timer/counters
• 8-bit input capture circuit
• Three timer outputs (including two PWM out-puts)
• Two event counter inputs (including one double-edge function)
• Clock-synchronous 8-bit serial interface
• A/D converter (4 channels × 8 bits)
• LCD controller/driver (52 segments × 4 commons)
• Built-in oscillators
Main clock: 4.2-MHz ceramic (an external clock is also possible)
Subclock: 32.768-kHz crystal
• Eleven interrupt sources
Five by external sources, including three double-edge functions
Page 4

HD404829R Series
Six by internal sources
• Subroutine stack up to 16 levels, including interrupts
• Four low-power dissipation modes
Subactive mode
Standby mode
Watch mode
Stop mode
• One external input for transition from stop mode to active mode
• Instruction cycle time (min.): 0.95 µs (f
• Operation voltage
VCC = 2.7 V to 6.0 V (HD404829R)
VCC = 2.7 V to 5.5 V (HD4074829)
• Two operating modes
MCU mode
MCU/PROM mode (HD4074829 only)
= 4.2 MHz)
OSC
2
Page 5

HD404829R Series
Ordering Information
Type Product Name Model Name ROM (Words) Package
Mask ROM HD404828R HD404828RH 8,192 100-pin plastic QFP
(FP-100B)
HD404828RFS 100-pin plastic QFP
(FP-100A)
HD404828RTF 100-pin plastic TQFP
(TFP-100B)
HD4048212R HD4048212RH 12,288 100-pin plastic QFP
(FP-100B)
HD4048212RFS 100-pin plastic QFP
(FP-100A)
HD4048212RTF 100-pin plastic TQFP
(TFP-100B)
HD404829R HD404829RH 16,384 100-pin plastic QFP
(FP-100B)
HD404829RFS 100-pin plastic QFP
(FP-100A)
HD404829RTF 100-pin plastic TQFP
(TFP-100B)
TM
ZTAT
HD4074829 HD4074829H 16,384 100-pin plastic QFP
(FP-100B)
HD4074829FS 100-pin plastic QFP
(FP-100A)
HD4074829TF 100-pin plastic TQFP
(TFP-100B)
Caution about operation!
It has been confirmed that the HD404829R Series, same as the ZTATTM version HD4074829 and the
conventional HD404829 Series, satisfies the electrical properties given on the data sheets, etc. However,
effective values of the electrical properties, the operating margin, and the noise margin may differ with the
manufacturing processes, on-chip ROM, and layout patterns. Therefore, conduct an evaluation test of your
system using the ZTATTM version and the mask ROM version. Also conduct a similar evaluation test for
checkup before replacing your conventional product with the HD404829R Series.
3
Page 6
HD404829R Series
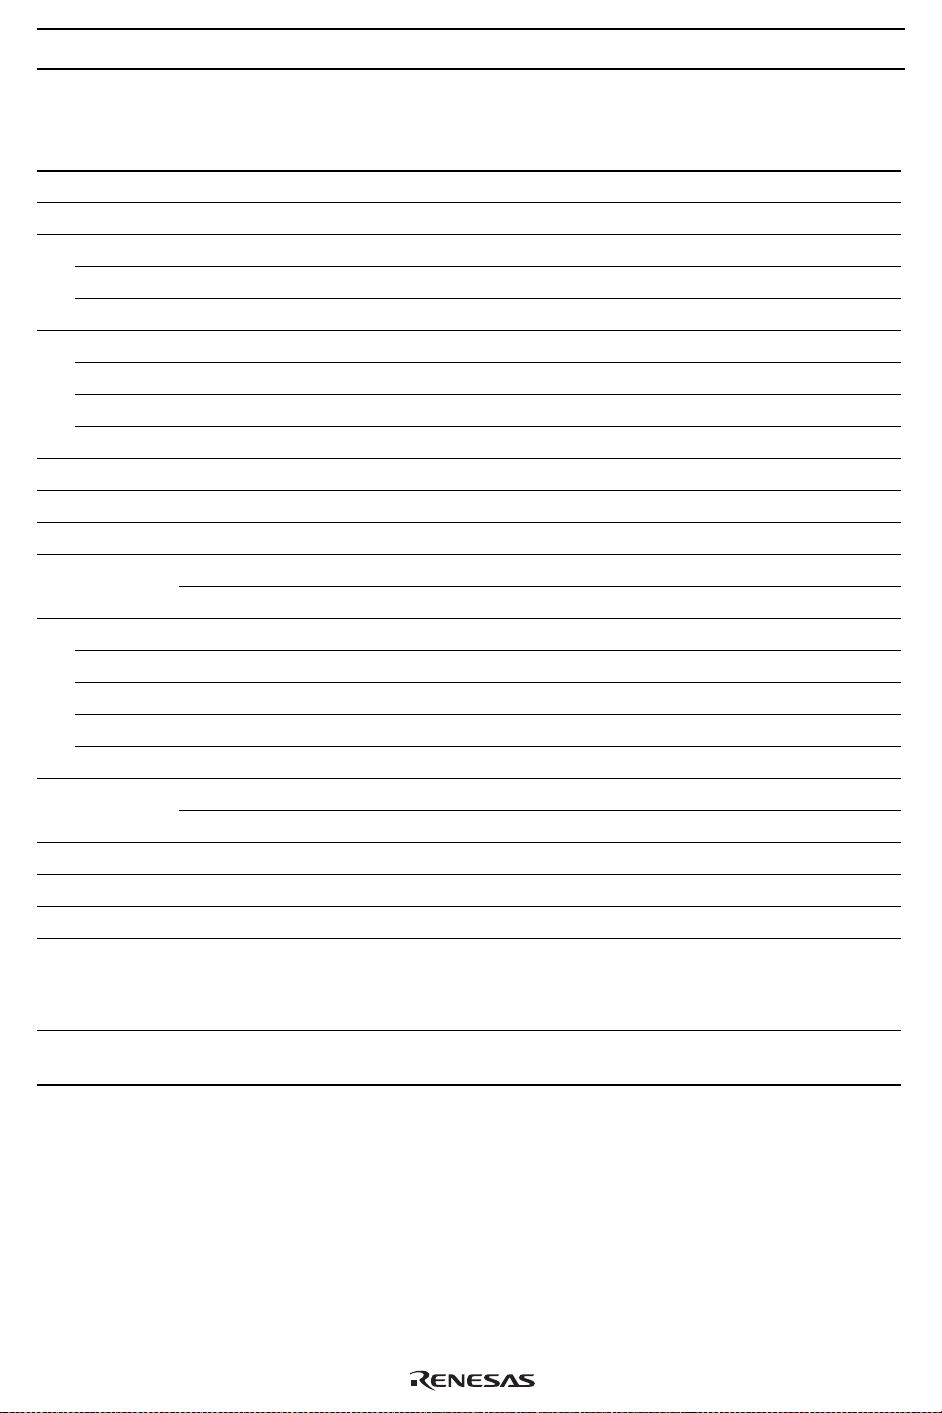
List of Functions
Product name HD404828R HD4048212R HD404829R HD4074829
ROM (Words) 8,192 12,288 16,384 16,384PROM
RAM (Digits) 1,876
I/O 44 (max)
Large-current I/O pins 10 (Sink 15 mA max)
LCD segment multiplexed pins 20
Timer / Counter 4
Input capture 8 bit × 1
Timer output 3 (PWM output possible for 2)
Event input 2 (edge selection possible for 1)
Serial interface 1 (8-bit syncronous)
A/D converter 8 bit × 4 channels
LCD controller / driver circuit Max. 52 seg × 4 com
Interrupts External 5 (edge selection possible for 3)
Internal 6
Low-Power Dissipation Mode 4
Stop mode O
Watch mode O
Standby mode O
Subactive mode O
Main Oscillator Ceramic oscillation O (0.4–4.2MHz)
Crystal oscillation O (0.4–4.2MHz) —
Sub oscillator Crystal oscillation O (32.768 kHz)
Minimum instruction execution time 0.95 µs (f
Operating voltage (V) 2.7 to 6.0 2.7 to 5.5
Package 100-pin plastic QFP (FP-100B)
100-pin plastic QFP (FP-100A)
100-pin plastic TQFP (TFP-100B)
Guaranteed operation temperature
(˚C)
= 4.2 MHz)
OSC
–20 to +75
4
Page 7
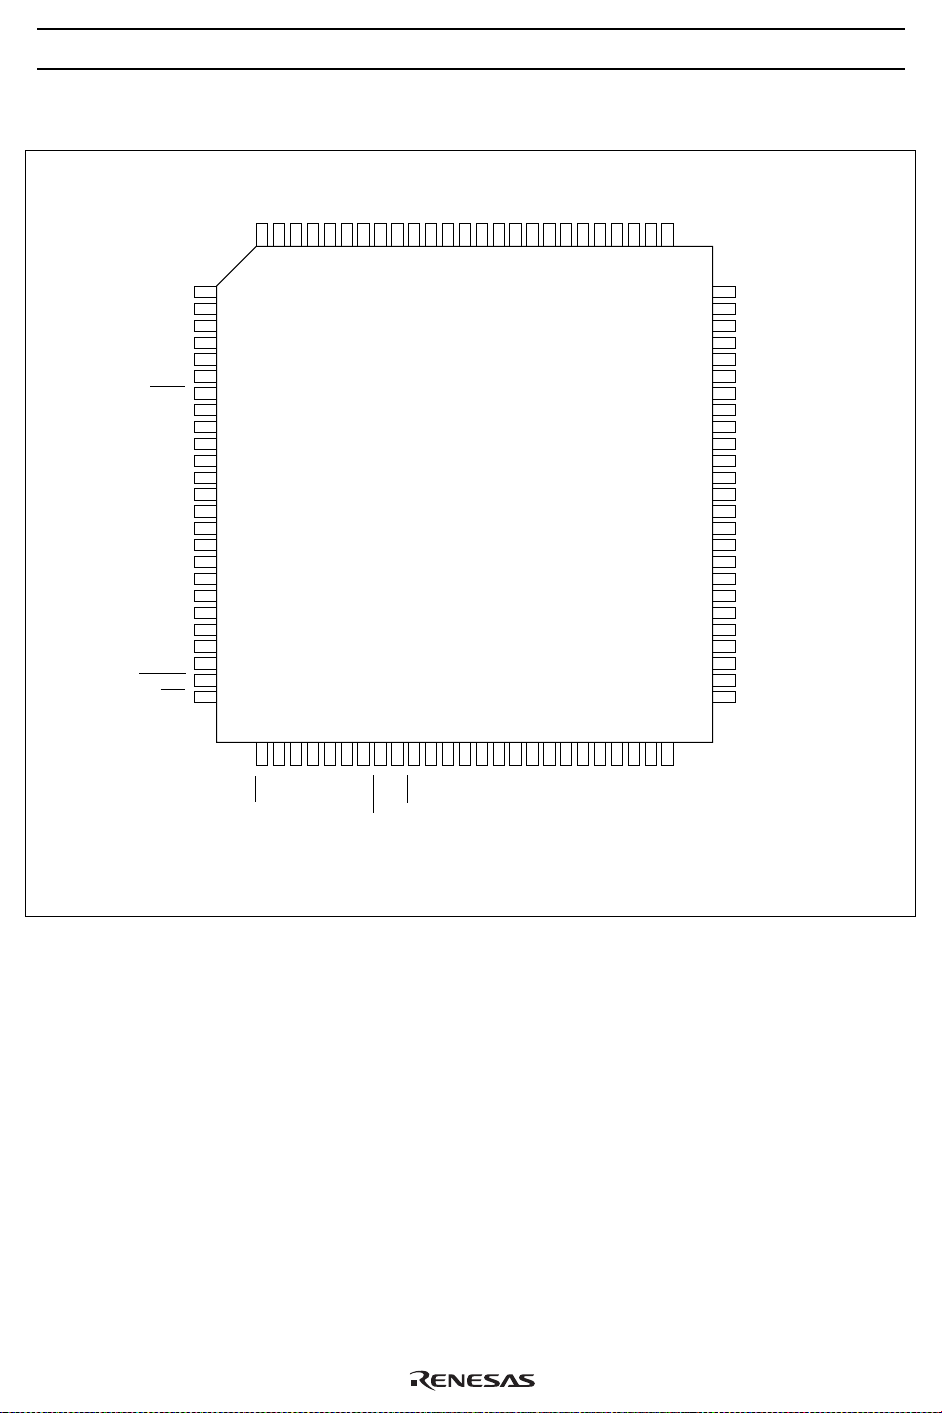
Pin Arrangement
NUMG
NUMO
CC32
NUMOVVVV
1
COM4
COM3
COM2
COM1
SEG52
SEG51
SEG50
SEG49
SEG48
SEG47
SEG46
SEG45
SEG44
SEG43
HD404829R Series
SEG42
SEG41
SEG40
SEG39
AV
CC
AN
AN
AN
AN
AV
TEST
OSC
OSC
RESET
X1
X2
GND
D
D
D
D
D
D
D
D
D
D
D /STOPC
10
D /INT
11 0
999897
100
1
2
0
3
1
4
2
5
3
6
SS
7
8
1
9
2
10
11
12
13
14
0
15
1
16
2
17
3
18
4
19
5
20
6
21
7
22
8
23
9
24
25
26
27
123
012
R0 /INT
R0 /INT
95949392919089888786858483828180797877
96
FP-100B
TFP-100B
28
29
30
31
32
33
34 3536
37
38
39
40
41
42
4
3
012
R0 /INT
R0 /INT
R1 /TOB
R1 /TOC
R1 /TOD
1
R2 /SI
3
0
R2 /SCK
R1 /EVNB
R2 /EVND
2
3
012301230
R2 /SO
R3 /SEG1
R3 /SEG2
R3 /SEG3
R3 /SEG4
R4 /SEG5
43
44 4546
R4 /SEG6
R4 /SEG7
R4 /SEG8
R5 /SEG9
76
47
48
49
50
123
R5 /SEG10
R5 /SEG11
R5 /SEG12
R6 /SEG13
SEG38
75
SEG37
74
SEG36
73
SEG35
72
SEG34
71
SEG33
70
SEG32
69
SEG31
68
SEG30
67
SEG29
66
SEG28
65
SEG27
64
SEG26
63
SEG25
62
SEG24
61
SEG23
60
SEG22
59
SEG21
58
R7 /SEG20
57
56
55
54
53
52
51
0
3
R7 /SEG19
2
R7 /SEG18
1
R7 /SEG17
0
R6 /SEG16
3
R6 /SEG15
2
R6 /SEG14
1
Top view
5
Page 8
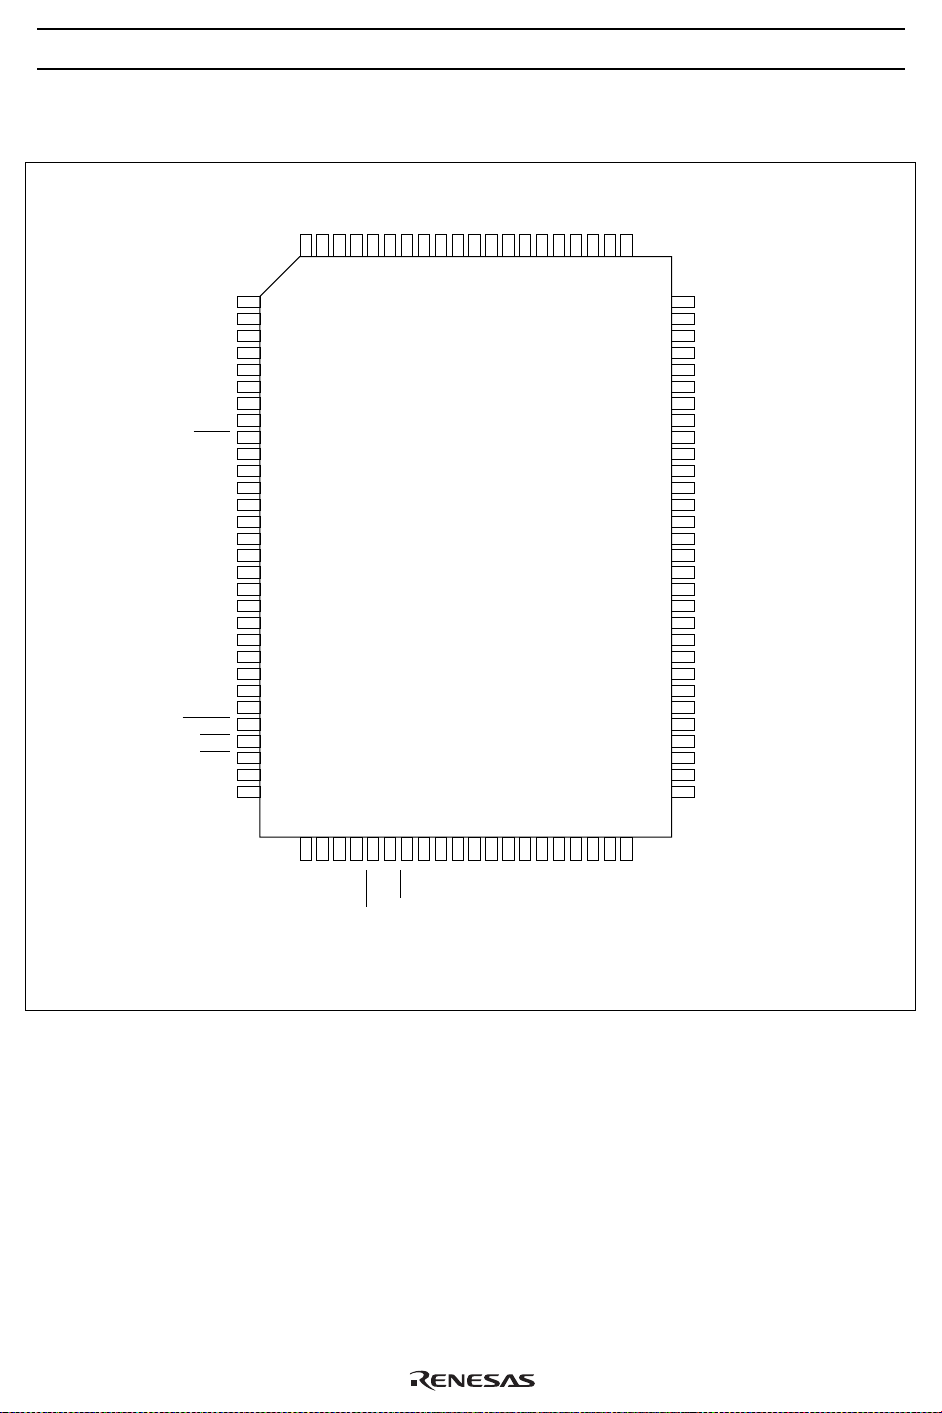
HD404829R Series
Pin Arrangement
NUMO
NUMG
AV
CC
AN
0
AN
1
AN
2
AN
3
AV
SS
TEST
OSC
1
OSC
2
RESET
X1
X2
GND
D
0
D
1
D
2
D
3
D
4
D
5
D
6
D
7
D
8
D
10
D /INT
11
R0 /INT
0
R0 /INT
1
R0 /INT
2
9
0
1
2
3
D /STOPC
CC32
NUMOVVVV
100
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
27
28
29
30
31323334353637383940414243444546474849
1
COM4
COM3
COM2
COM1
SEG52
SEG51
SEG50
SEG49
99989796959493929190898887868584838281
FP-100A
SEG48
SEG47
SEG46
SEG45
SEG44
SEG43
SEG42
80
79
78
77
76
75
74
73
72
71
70
69
68
67
66
65
64
63
62
61
60
59
58
57
56
55
54
53
52
51
50
SEG41
SEG40
SEG39
SEG38
SEG37
SEG36
SEG35
SEG34
SEG33
SEG32
SEG31
SEG30
SEG29
SEG28
SEG27
SEG26
SEG25
SEG24
SEG23
SEG22
SEG21
R7 /SEG20
3
R7 /SEG19
2
R7 /SEG18
1
R7 /SEG17
0
R6 /SEG16
3
R6 /SEG15
2
R6 /SEG14
1
R6 /SEG13
0
R5 /SEG12
3
43
012
R1 /TOB
R1 /TOC
R0 /INT
R1 /TOD
1
R2 /SI
0
3
R2 /SCK
R1 /EVNB
R2 /EVND
2
3
012301230
R2 /SO
R3 /SEG1
R3 /SEG2
R3 /SEG3
R3 /SEG4
R4 /SEG5
R4 /SEG6
R4 /SEG7
R4 /SEG8
1
2
R5 /SEG9
R5 /SEG10
R5 /SEG11
Top view
6
Page 9

HD404829R Series
Pin Description
Pin Number
FP-100B
Item Symbol
Power V
supply
CC
GND 13 15 Connected to ground
Test TEST 7 9 I Used for factory testing only: Connect this pin to V
Reset RESET 10 12 I Resets the MCU
Oscillator OSC
OSC
1
2
X1 11 13 I Used for a 32.768-kHz crystal for clock purposes.
X2 12 14 O If not to be used, fix the X1 pin to VCC and leave
Port D0–D
9
D10, D
R00–R7
11
3
Interrupt INT0, INT1,
INT2–INT
4
Stop clear STOPC 24 26 I Input pin for transition from stop mode to active
Serial SCK 35 37 I/O Serial interface clock input/output pin
interface
SI 36 38 I Serial interface receive data input pin
SO 37 39 O Serial interface transmit data output pin
Timer TOB, TOC,
TOD
EVNB, EVND 33, 34 35, 36 I Event count input pins
LCD V1, V2, V
3
COM1–COM4 90–93 92–95 O Common signal pins for LCD
SEG1–SEG52 38–89 40–91 O Segment signal pins for LCD
TFP-100B FP-100A I/O Function
97 99 Applies power voltage
8 10 I Input/output pins for the internal oscillator circuit:
9 11 O Connect them to a ceramic oscillator ,crystal
oscillator or connect OSC1 to an external oscillator
curcuit
the X2 pin open.
14–23 16–25 I/O Input/output pins addressed by individual bits; pins
D0–D9 are high-current pins that can each supply up
to 15 mA
24, 25 26, 27 I Input pins addressable by individual bits
26–57 28–59 I/O Input/output pins addressable in 4-bit units
25–29 27–31 I Input pins for external interrupts
mode
30–32 32–34 O Timer output pins
94–96 96–98 Power pins for LCD controller/driver; may be left
open during operation since they are connected by
internal voltage division resistors.
Voltage conditions are: VCC ≥ V1 ≥ V2 ≥ V3 ≥ GND
CC
7
Page 10

HD404829R Series
Pin Number
FP-100B
Item Symbol
A/D
AV
CC
converter
AV
SS
AN0–AN
NUMG NUMG 100 2 These are not pins for user applications. Connect
NUMO NUMO 98,99 100,1 NUMG to the same potential as GND. Leave NUMO
TFP-100B FP-100A I/O Function
1 3 Power pin for A/D converter: Connect it to the same
potential as VCC, as physically close to the VCC pin as
possible
6 8 Ground for AVCC: Connect it to the same potential
as GND, as physically close to the GND pin as
possible
2–5 4–7 I Analog input pins for A/D converter
3
.
open
8
Page 11

Block Diagram
RESET
TEST
STOPCOSC1OSC2X1X2VCCGND
HD404829R Series
INT
0
INT
1
INT
2
INT
3
INT
4
EVNB
TOB
TOC
EVND
TOD
SCK
SI
SO
AV
cc
AV
ss
AN
0
AN
1
AN
2
AN
3
V
1
V
2
V
3
COM1
COM2
COM3
COM4
SEG1
SEG2
SEG3
~
SEG52
HMCS400 CPU
ROM
External interrupt
control circuit
Timer A
8-bit free-running timer
8-bit free-running / reload timer
8-bit free-running / reload timer
Timer B
Timer C
Timer D
8-bit free-running / reload timer
Clock-synchronous
8-bit serial interface
A/D converter
4 channels x 8 bits
LCD controller / driver
52 segments x 4 commons
RAM
circuit
D Port
R0 Port
R1 Port
R2 Port
R4 Port R3 Port
R5 Port
R6 Port
R7 Port
D
0
D
1
D
2
D
3
D
4
D
5
D
6
D
7
D
8
D
9
D
10
D
11
R0
0
R0
1
R0
2
R0
3
R1
0
R1
1
R1
2
R1
3
R2
0
R2
1
R2
2
R2
3
R3
0
R3
1
R3
2
R3
3
R4
0
R4
1
R4
2
R4
3
R5
0
R5
1
R5
2
R5
3
R6
0
R6
1
R6
2
R6
3
R7
0
R7
1
R7
2
R7
3
~
: High current pins
9
Page 12
HD404829R Series
Memory Map
ROM Memory Map
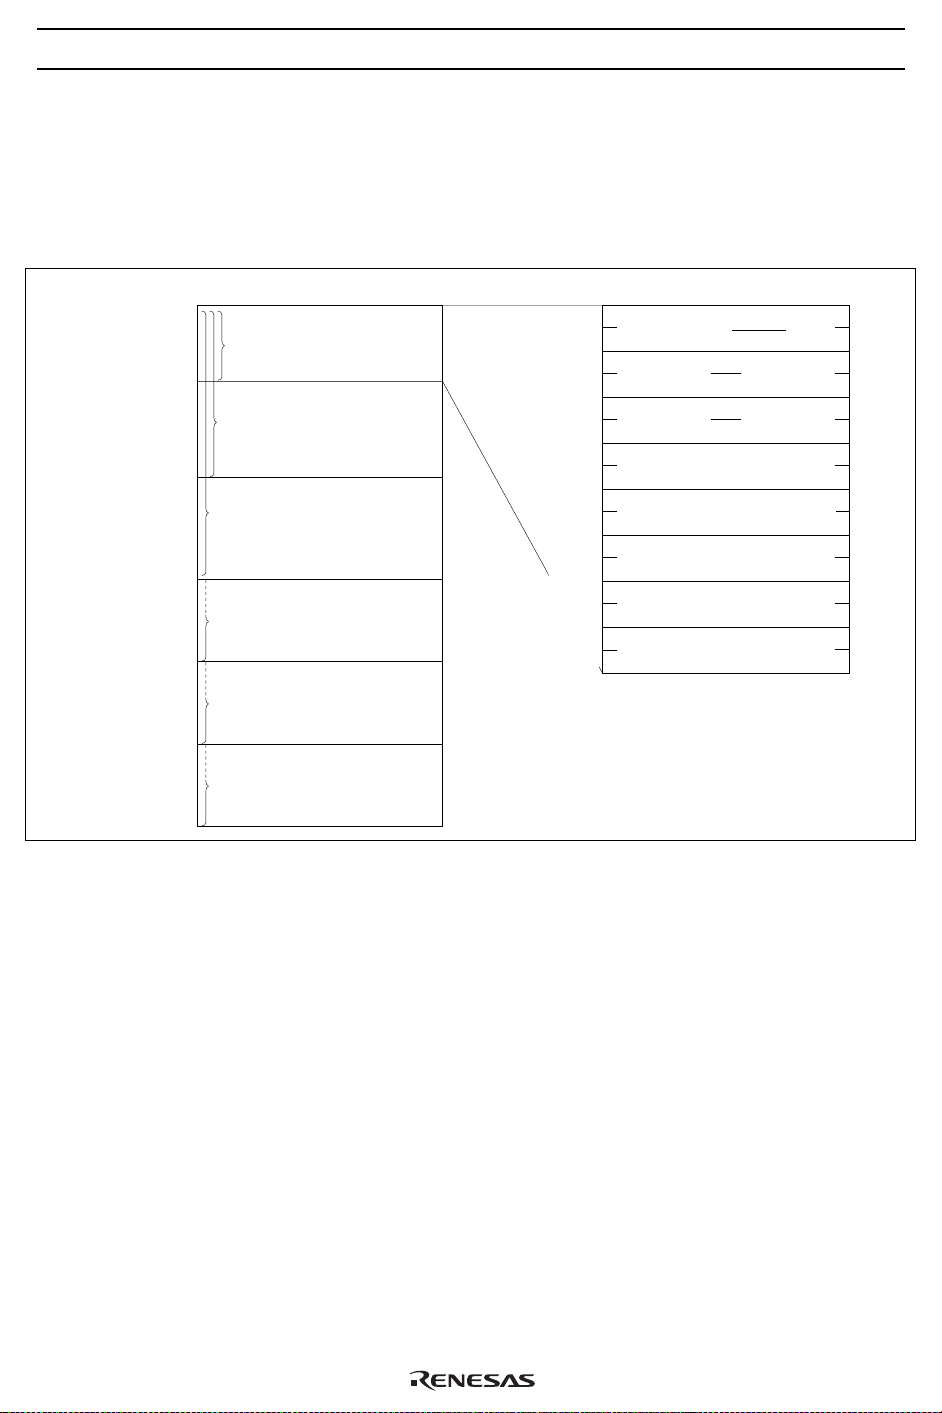
The ROM memory map is shown in figure 1 and described below.
ROM address ROM address
$0000
$000F
$0010
$003F
$0040
$0FFF
$1000
$1FFF
$2000
$2FFF
$3000
$3FFF
Vector address
Zero-page subroutine
(64 words)
Pattern
(4096 words)
HD404828R
Program
(8,192 words)
HD4048212R
Program
(12,288 words)
HD404829R, HD4074829
Program
(16,384 words)
$0000
$0001
$0002
$0003
$0004
$0005
$0006
$0007
$0008
$0009
$000A
$000B
$000C
$000D
$000E
$000F
(jump to RESET, STOPC routine)
JMPL instruction
JMPL instruction
(jump to INT routine)
JMPL instruction
(jump to INT routine)
JMPL instruction
(jump to timer A routine)
JMPL instruction
(jump to timer B, INT routine)
JMPL instruction
(jump to timer C, INT routine)
JMPL instruction
(jump to timer D, INT routine)
JMPL instruction
(jump to A/D, serial routine)
0
1
2
3
4
Figure 1 ROM Memory Map
Vector Address Area ($0000–$000F): Reserved for JMPL instructions that branch to the start addresses
of the reset and interrupt routines. After MCU reset or an interrupt, program execution continues from the
vector address.
Zero-Page Subroutine Area ($0000–$003F): Reserved for subroutines. The program branches to a
subroutine in this area in response to the CAL instruction.
Pattern Area ($0000–$0FFF): Contains ROM data that can be referenced with the P instruction.
Program Area ($0000–$1FFF: HD404828R; $0000–$2FFF: HD4048212R; $0000–$3FFF;
HD404829R, HD4074829): Used for program coding.
10
Page 13
HD404829R Series
RAM Memory Map
The MCU contains a 1,876-digit × 4-bit RAM area consisting of a memory register area, an LCD data area,
a data area, and a stack area. In addition, an interrupt control bits area, special register area, and register
flag area are mapped onto the same RAM memory space as a RAM-mapped register area outside the above
areas. The RAM memory map is shown in figure 2 and described below.
RAM-Mapped Register Area ($000–$03F):
• Interrupt Control Bits Area ($000–$003)
This area is used for interrupt control bits (figure 3). These bits can be accessed only by RAM bit
manipulation instructions (SEM/SEMD, REM/REMD, and TM/TMD). However, note that not all the
instructions can be used for each bit. Limitations on using the instructions are shown in figure 4.
• Special Function Register Area ($004–$01F, $024–$03F)
This area is used as mode registers and data registers for external interrupts, serial interface,
timer/counters, LCD, A/D converter, and as data control registers for I/O ports. The structure is shown
in figures 2 and 5. These registers can be classified into three types: write-only (W), read-only (R), and
read/write (R/W). The SEM, SEMD, REM, and REMD instructions can be used for the LCD control
register (LCR: $01B), but RAM bit manipulation instructions cannot be used for other registers.
• Register Flag Area ($020–$023)
This area is used for the DTON, WDON, and other register flags and interrupt control bits (figure 3).
These bits can be accessed only by RAM bit manipulation instructions (SEM/SEMD, REM/REMD, and
TM/TMD). However, note that not all the instructions can be used for each bit. Limitations on using
the instructions are shown in figure 4.
11
Page 14

HD404829R Series
RAM address RAM address
$000
$040
Memory registers (16 digits)
$050
LCD display area (52 digits)
$084
$090
$260
$3C0
$3FF
$090
Data
(464 digits)
V = 0
(bank = 0)
$25F
Notes: 1.
The data area has three banks:
bank 0 (V = 0) to bank 2 (V = 2).
2.
Two registers are mapped
on the same area.
R:
W:
R/W:
RAM-mapped registers
Not used
Data
V = 1
(bank = 1)
×
Data (464 digits 3)
V = 0 (bank 0)
V = 1 (bank 1)
V = 2 (bank 2)
Data (352 digits)
Stack (64 digits)
(464 digits)
Read only
Write only
Read/write
*1
Data
(464 digits)
V = 2
(bank = 2)
$000
$003
$004
$005
$006
$007
$008
$009
$00A
$00B
$00C
$00D
$00E
$00F
$010
$011
$012
$013
$014
$015
$016
$017
$018
$01B
$01C
$01D
$01E
$01F
$020
$023
$024
$025
$026
$027
$028
$029
$02A
$02B
$02C
$02D
$02E
$02F
$030
$031
$032
$033
$034
$035
$036
$037
$038
$03E
$03F
Interrupt control bits area
Port mode register A (PMRA)
Serial mode register A (SMRA)
Serial data register lower (SRL)
Serial data register upper (SRU)
Timer mode register A (TMA)
Timer mode register B1 (TMB1)
Timer B (TRBL/TWBL)
(TRBU/TWBU)
Miscellaneous register (MIS)
Timer mode register C1 (TMC1)
Timer C (TRCL/TWCL)
(TRCU/TWCU)
Timer mode register D1 (TMD1)
Timer D (TRDL/TWDL)
(TRDU/TWDU)
Timer mode register B2 (TMB2)
Timer mode register C2 (TMC2)
Timer mode register D2 (TMD2)
A/D mode register (AMR)
A/D data register lower (ADRL)
A/D data register upper (ADRU)
Not used
LCD control register (LCR)
LCD mode register (LMR)
LCD output register 1 (LOR1)
LCD output register 2 (LOR2)
LCD output register 3 (LOR3)
Register flag area
Port mode register B (PMRB)
Port mode register C (PMRC)
Detection edge select register 1 (ESR1)
Detection edge select register 2 (ESR2)
Serial mode register B (SMRB)
System clock select register (SSR)
Not used
Port D
Port D
Port D
Port R0 DCR (DCR0)
Port R1 DCR (DCR1)
Port R2 DCR (DCR2)
Port R3 DCR (DCR3)
Port R4 DCR (DCR4)
Port R5 DCR (DCR5)
Port R6 DCR (DCR6)
Port R7 DCR (DCR7)
V register (V)
DCR (DCD0)
0–D3
DCR (DCD1)
4–D7
and D9 DCR (DCD2)
8
Not used
Not used
W
W
R/W
R/W
W
W
R/W
R/W
W
W
R/W
R/W
W
R/W
R/W
R/W
R/W
R/W
W
R
R
W
W
W
W
W
W
W
W
W
W
W
W
W
W
W
W
W
W
W
W
W
W
R/W
*2
12
Timer read register B lower (TRBL)
10
Timer read register B upper (TRBU)
11
14
Timer read register C lower (TRCL)
15
Timer read register C upper (TRCU)
Timer read register D lower (TRDL)
17
18
Timer read register D upper (TRDU)
Figure 2 RAM Memory Map
Timer write register B lower (TWBL)
R
R
Timer write register B upper (TWBU)
R
Timer write register C lower (TWCL)
R
Timer write register C upper (TWCU)
R
Timer write register D lower (TWDL)
Timer write register D upper (TWDU)
R
$00A
W
$00B
W
$00E
W
$00F
W
$011
W
W
$012
Page 15

HD404829R Series
RAM address
$000
$001
$002
$003
$020
$021
$022
$023
Bit 3
IM0
(IM of INT
(IM of timer A)
(IM of timer C)
(IM of A/D)
(Direct transfer
(RAM enable
(IM of
(IM of serial
interface)
IMTA
IMTC
IMAD
Bit 3
DTON
on flag)
RAME
flag)
IM3
INT
IMS
0
3
)
)
Bit 2 Bit 1
IF0
(IF of INT
(IF of timer A)
(IF of timer C)
(IF of A/D)
(A/D start flag)
Not used
(IF of INT
(IF of serial
interface)
)
0
IFTA
IFTC
IFAD
Interrupt control bits area
Bit 2 Bit 1
ADSF
IF3
)
3
IFS
Register flag area
RSP
(Reset SP bit)
IM1
(IM of INT
(IM of timer B)
(IM of timer D)
(Watchdog
(Input capture
(IM of INT2)
(IM of
IMTB
IMTD
WDON
on flag)
ICEF
error flag)
IM2
IM4
INT
1
4
)
)
Bit 0
IE
(Interrupt
enable flag)
IF1
(IF of INT1)
IFTB
(IF of timer B)
IFTD
(IF of timer D)
Bit 0
LSON
(Low speed
on flag)
ICSF
(Input capture
status flag)
IF2
(IF of INT2)
IF4
(IF of INT4)
Interrupt request flag
IF:
Interrupt mask
IM:
Interrupt enable flag
IE:
Stack pointer
SP:
Figure 3 Configuration of Interrupt Control Bits and Register Flag Areas
SEM/SEMD REM/REMD TM/TMD
IE
IM
Allowed Allowed Allowed
LSON
IF
ICSF
ICEF
Not executed Allowed Allowed
RAME
RSP
WDON
ADSF
DTON
Not used
Not executed Allowed Inhibited
Allowed Not executed Inhibited
Allowed Inhibited Allowed
Not executed in active mode
Used in subactive mode
Allowed Allowed
Not executed Not executed Inhibited
Note: WDON is reset by MCU reset or by STOPC enable for stop mode cancellation.
The REM or REMD instuction must not be executed for ADSF during A/D conversion.
DTON is always reset in active mode.
If the TM or TMD instruction is executed for the inhibited bits or non-existing bits,
the value in ST becomes invalid.
Figure 4 Usage Limitations of RAM Bit Manipulation Instructions
13
Page 16

HD404829R Series
$000
$003
PMRA $004
SMRA $005
SRL $006
SRU $007
TMA $008
TMB1 $009
TRBL/TWBL $00A
TRBU/TWBU $00B
MIS $00C
TMC1 $00D
TRCL/TWCL $00E
TRCU/TWCU $00F
TMD1 $010
TRDL/TWDL $011
TRDU/TWDU $012
TMB2 $013
TMC2 $014
TMD2 $015
AMR $016
ADRL $017
ADRU $018
LCR $01B
LMR $01C
LOR1 $01D
LOR2 $01E
LOR3 $01F
$020
$023
PMRB $024
PMRC $025
ESR1 $026
ESR2 $027
SMRB $028
SSR $029
DCD0 $02C
DCD1 $02D
DCD2 $02E
DCR0 $030
DCR1 $031
DCR2 $032
DCR3 $033
DCR4 $034
DCR5 $035
DCR6 $036
DCR7 $037
V $03F
Bit 3 Bit 2 Bit 1
Bit 0
Interrupt control bits area
Not used Not used R2
R21/SCK
Serial transmit clock speed selection
/SI R23/SO
2
Serial data register (lower digit)
Serial data register (upper digit)
*
1
*
2
Clock source setting (timer A)
Clock source setting (timer B)
Timer B register (lower digit)
Timer B register (upper digit)
*
3
*
2
R23/SO PMOS control
Interrupt frame period selection
Clock source setting (timer C)
Timer C register (lower digit)
Timer C register (upper digit)
*
2
Clock source setting (timer D)
Timer D register (lower digit)
Timer D register (upper digit)
Not used Not used Timer-B output mode selection
Not used
*
4
Analog channel selection
Timer-C output mode setting
Timer-D output mode setting
Not used
A/D data register (lower digit)
A/D data register (upper digit)
Not used
Not used
*
6
*
7
*
LCD duty cycle selectionLCD input clock source selection
R3
/SEG4
3
/SEG8
R4
3
Not used
R3
/SEG3
2
/SEG7
R4
2
R7/SEG17–20
R31/SEG2
R4
/SEG6
1
R6/SEG13–16
R30/SEG1
R4
/SEG5
0
R5/SEG9–12
Register flag area
R0
4
0
/INT
2
D10/STOPC
R03/INT
D11/INT
detection edge selection
INT
3
EVND detection edge selection
Not used Not used
*
11
*
12
R0
/INT
1
3
R20/EVND
INT
detection edge selection
2
INT
detection edge selection
4
*
9
*
13
2
R00/INT
R13/EVNB
*
Not used
Not used
DCR
3
DCR
7
DCR
3
DCR
3
DCR
3
DCR
3
DCR
3
DCR
3
DCR
3
DCR
3
Port D
Port D
Not used
Port R0
Port R1
Port R2
Port R3
Port R4
Port R5
Port R6
Port R7
2
DCR
6
DCR
2
DCR
2
DCR
2
DCR
2
DCR
2
DCR
2
DCR
2
DCR
2
Port D
Port D
Port D
Not used
Port R0
Port R1
Port R2
Port R3
Port R4
Port R5
Port R6
Port R7
DCR
1
DCR
5
DCR
9
DCR
1
DCR
1
DCR
1
DCR
1
DCR
1
DCR
1
DCR
1
DCR
1
Port D
Port D
Port D
Port R0
Port R1
Port R2
Port R3
Port R4
Port R5
Port R6
Port R7
Port D
Port D
Not used
Port R0
Port R1
Port R2
Port R3
Port R4
Port R5
Port R6
Port R7
DCR
Not used
Not used Not used Bank 0 to bank 2 selection
*
5
8
10
DCR
0
DCR
4
DCR
8
0
0
0
0
0
0
0
0
1
DCR
DCR
DCR
DCR
DCR
DCR
DCR
DCR
Notes:
Timer-A/time-base
1.
Auto-reload on/off
2.
Pull-up MOS control
3.
Input capture selection
4.
A/D conversion time
5.
Display on/off in watch mode
6.
LCD power switch
7.
LCD display on/off
8.
SO idle H/L setting
9.
Transmit clock source selection
10.
32-kHz oscillation stop setting
11.
32-kHz oscillation division ratio
12.
System clock selection
13.
14
Figure 5 Special Function Register Area
Page 17

HD404829R Series
Memory Register (MR) Area ($040–$04F): Consisting of 16 addresses, this area (MR0–MR15) can be
accessed by register-register instructions (LAMR and XMRA). The structure is shown in figure 6.
Memory registers
$040
$041
$042
$043
$044
$045
$046
$047
$048
$049
$04A
$04B
$04C
$04D
$04E
$04F
MR(0)
MR(1)
MR(2)
MR(3)
MR(4)
MR(5)
MR(6)
MR(7)
MR(8)
MR(9)
MR(10)
MR(11)
MR(12)
MR(13)
MR(14)
MR(15)
PC –PC :
13
ST: Status flag
Program counter
0
CA: Carry flag
Figure 6 Configuration of Memory Registers and Stack Area, and Stack Position
Stack area
960 $3C0
Level 16
Level 15
Level 14
Level 13
Level 12
Level 11
Level 10
Level 9
Level 8
Level 7
Level 6
Level 5
Level 4
Level 3
Level 2
1023
Level 1
$3FF
$3FC
$3FD
$3FE
$3FF
Bit 3 Bit 2 Bit 1 Bit 0
ST
PC
CA
PC
PC
PC
10
PC
PC
3
PC
13
PC
9
PC
6
PC
2
PC
12
PC
8
PC
5
PC
1
11
7
4
0
15
Page 18
HD404829R Series
LCD Data Area ($050–$083): Used for storing 52-digit LCD data which is automatically output to LCD
segments as display data. Data 1 lights the corresponding LCD segment; data 0 extinguishes it. Refer to
the LCD description for details.
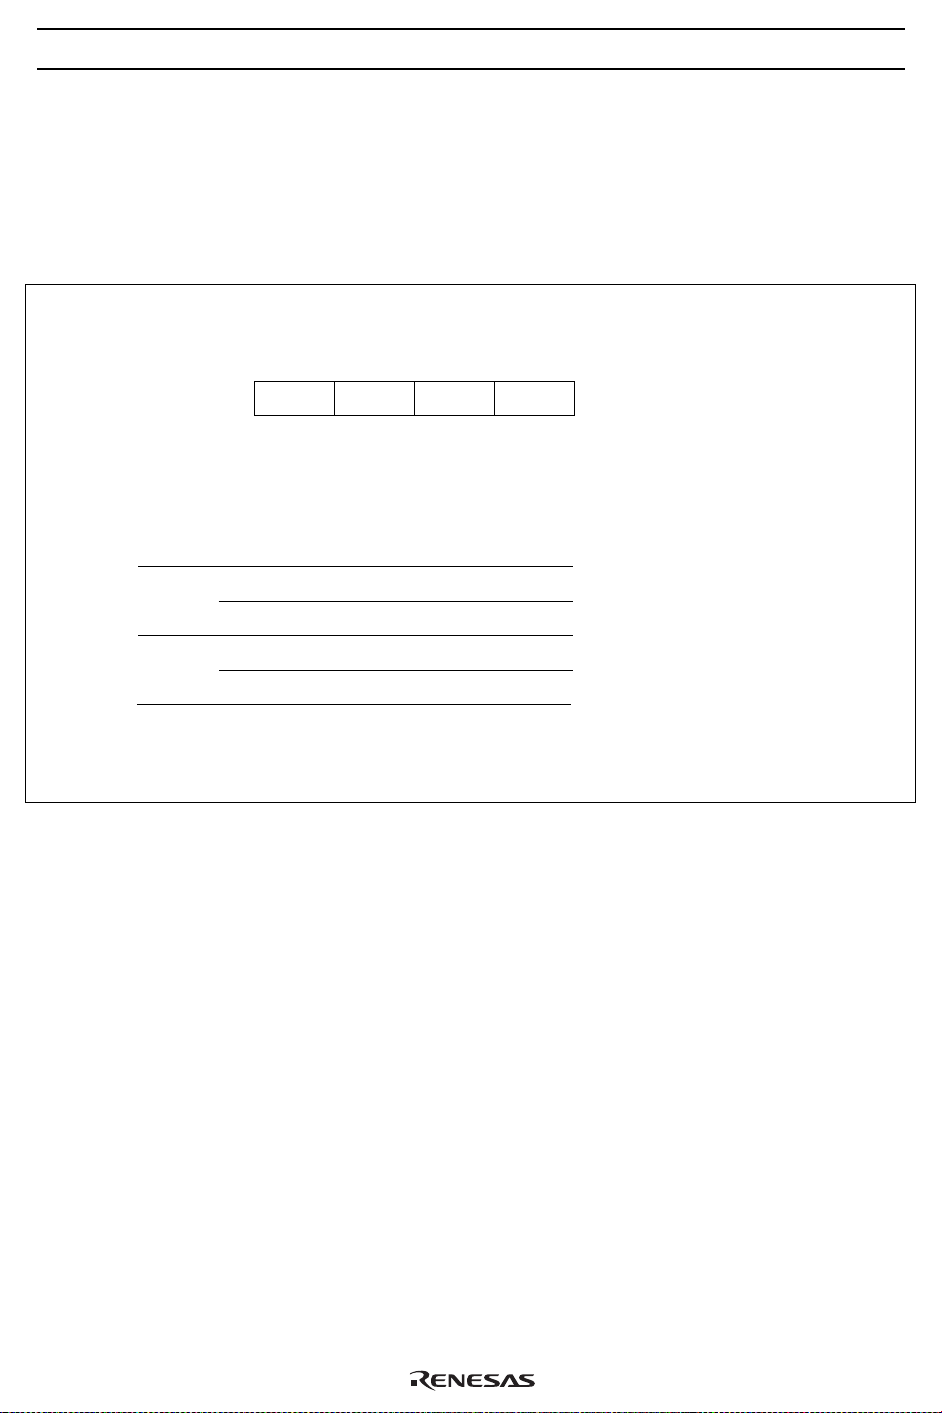
Data Area ($090–$3BF): 464 digits from $090 to $25F have three banks, which can be selected by setting
the bank register (V: $03F). Before accessing this area, set the bank register to the required value (figure
7). The area from $260 to $3BF is accessed without setting the bank register.
Bank register (V: $03F)
Bit
Initial value
Read/Write
Bit name
V1
0
1
Note: After reset, the value in the bank register is 0, and therefore bank 0 is
selected. If V1 = 1 and V0 = 1, no bank is selected, and the operation is not
guaranteed.
3
—
—
Not used
V0
0
1
0
1
2
—
—
Not used
Bank area selection
Bank 0 is selected
Bank 1 is selected
Bank 2 is selected
Not used
1
0
R/W
V1
0
0
R/W
V0
Figure 7 Bank Register (V)
Stack Area ($3C0–$3FF): Used for saving the contents of the program counter (PC), status flag (ST), and
carry flag (CA) at subroutine call (CAL or CALL instruction) and for interrupts. This area can be used as a
16-level nesting subroutine stack in which one level requires four digits. The data to be saved and the save
conditions are shown in figure 6.
The program counter is restored by either the RTN or RTNI instruction, but the status and carry flags can
only be restored by the RTNI instruction. Any unused space in this area is used for data storage.
16
Page 19
HD404829R Series
Functional Description
Registers and Flags
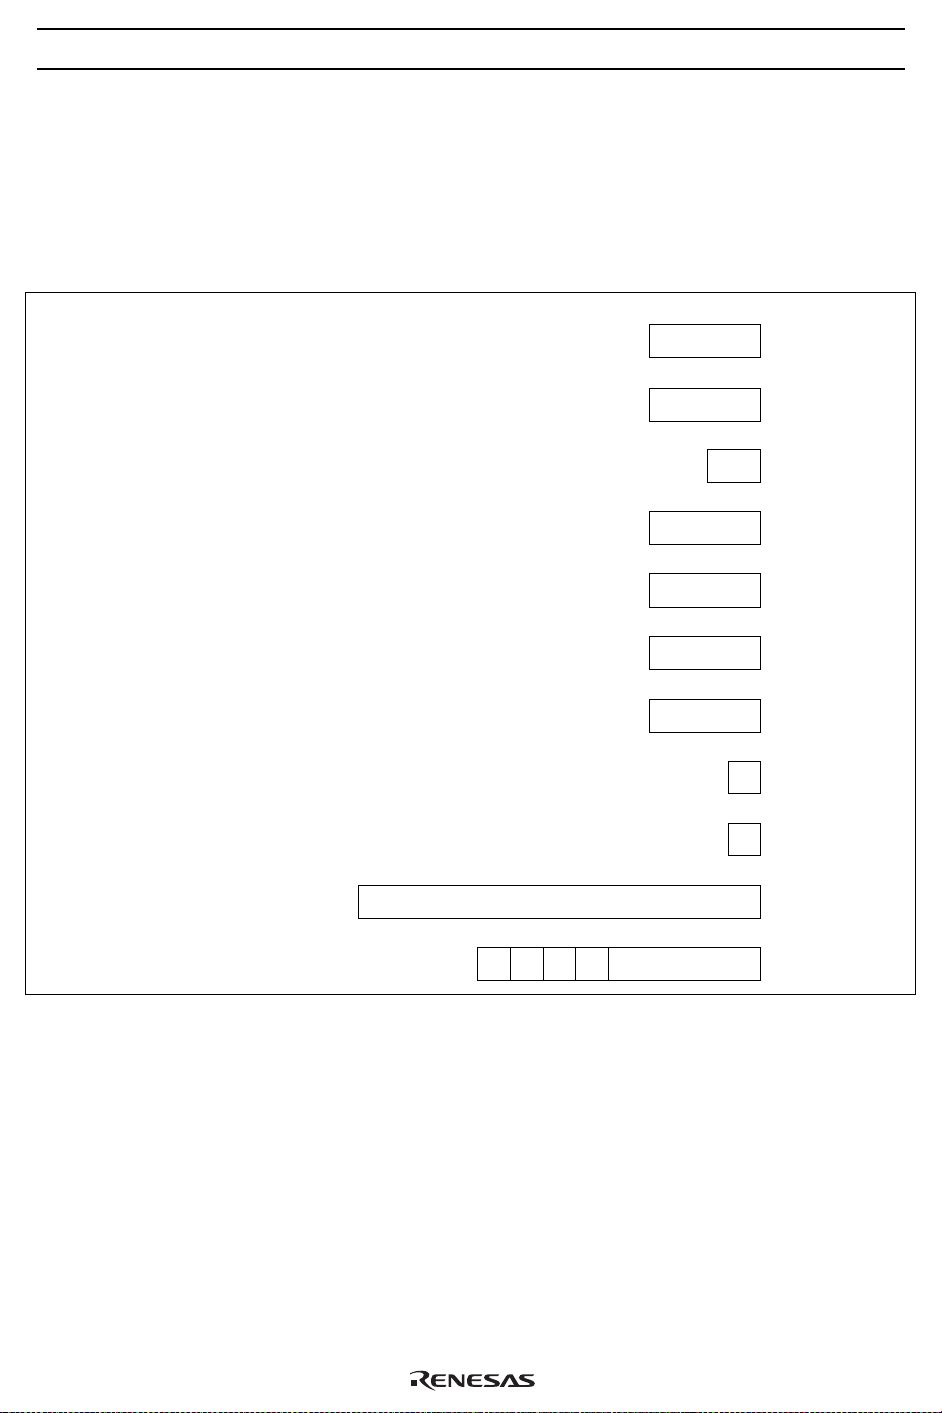
The MCU has nine registers and two flags for CPU operations. They are shown in figure 8 and described
below.
30
Accumulator
B register
W register
X register
Y register
SPX register
Initial value: Undefined, R/W
Initial value: Undefined, R/W
Initial value: Undefined, R/W
Initial value: Undefined, R/W
Initial value: Undefined, R/W
Initial value: Undefined, R/W
(A)
30
(B)
0
1
(W)
30
(X)
30
(Y)
30
(SPX)
30
SPY register
Carry
Status
Program counter
Initial value: $0000,
R/W not possible
Stack pointer
Initial value: $3FF, R/W not possible
Initial value: Undefined, R/W
Initial value: Undefined, R/W
Initial value: 1, R/W not possible
13
95
1111
(SPY)
0
(CA)
0
(ST)
0
(PC)
0
(SP)
Figure 8 Registers and Flags
Accumulator (A) and B Register (B)
A and B are 4-bit registers, and are used to hold the results of ALU(arithmetic and logical unit) operations
and to transfer data between memory, I/O ports, and other registers.
W Register (W), X Register (X), Y Register (Y)
W is a 2-bit register and X and Y are 4-bit registers. These registers are used in RAM register indirect
addressing. The Y register is also used in D port addressing.
17
Page 20

HD404829R Series
SPX Register (SPX) and SPY Register (SPY)
The SPX and SPY registers are 4-bit registers used to supplement the X and Y registers.
Carry Flag (CA)
CA is a 1-bit flag that stores ALU overflow generated by an arithmetic operation. CA is set to 1 when an
overflow is generated, and is cleared to 0 after operations in which no overflow occurred. CA is also
affected by the carry set/carry clear instructions (SEC and REC), and by the rotate with carry instructions
(ROTL and ROTR.)
During interrupt handling, CA is saved on the stack, and is restored from the stack by the RTNI instruction.
Status Flag (ST)
ST is a 1-bit flag that stores the results of arithmetic instructions, compare instructions, and bit test
instructions, and is used as the branch condition for the BR, BRL, CAL, and CALL conditional branch
instructions.
The contents of the ST flag are held until the next arithmetic, compare, bit test, or conditional branch
instruction is executed. After the execution of a conditional branch instruction, the value of ST is set to 1
without regard to the condition.
During interrupt handling, ST is saved on the stack, and is restored from the stack by the RTNI instruction.
Program Counter (PC)
The PC is a 14-bit counter that indicates the ROM address of the next instruction the CPU will execute.
Stack Pointer (SP)
The SP is a 10-bit register that indicates the RAM address of the next stack frame in the stack area.
The SP is initialized to $3FF by a reset. The SP is decremented by 4 by a subroutine call or by interrupt
handling, and is incremented by 4 when the saved data has been restored by a return instruction.
The upper 4 bits of the SP are fixed at 1111; the maximum number of stack levels is thus 16.
In addition to the reset method described above, the SP can also be initialized to $3FF by clearing the reset
stack pointer (RSP) in the interrupt control bits area with a RAM bit manipulation instruction, i.e., REM or
REMD.
Reset
The MCU is reset by inputting a high-level voltage to the RESET pin. At power-on or when stop mode is
cancelled, RESET must be high for at least one t
RESET must be high for at least two instruction cycles.
to enable the oscillator to stabilize. During operation,
R C
Initial values after MCU reset are listed in table 1.
18
Page 21

HD404829R Series
Table 1 Initial Values After MCU Reset
Initial
Item Abbr.
Program
counter
Status flag (ST) 1 Enables conditional branching
Stack pointer (SP) $3FF Stack level 0
Interrupt Interrupt enable flag (IE) 0 Inhibits all interrupts
flags/mask
I/O Port data register (PDR) All bits 1 Enables output at level 1
Timer/ Timer mode register A (TMA) 0000 Refer to description of timer mode register A
counters, Timer mode register B1 (TMB1) 0000 Refer to description of timer mode register B1
serial Timer mode register B2 (TMB2) - - 00 Refer to description of timer mode register B2
interface Timer mode register C1 (TMC1) 0000 Refer to description of timer mode register C1
Interrupt request flag (IF) 0 Indicates there is no interrupt request
Interrupt mask (IM) 1 Prevents (masks) interrupt requests
Data control register (DCD0,
Port mode register A (PMRA) - - 00 Refer to description of port mode register A
Port mode register B (PMRB) 0000 Refer to description of port mode register B
Port mode register C
bits 3, 1, 0
Detection edge select
register 1
Detection edge select
register 2
Timer mode register C2 (TMC2) - 000 Refer to description of timer mode register C2
Timer mode register D1 (TMD1) 0000 Refer to description of timer mode register D1
Timer mode register D2 (TMD2) 0000 Refer to description of timer mode register D2
Serial mode register A (SMRA) 0000 Refer to description of serial mode register A
Serial mode register B (SMRB) - - x0 Refer to description of serial mode register B
Prescaler S (PSS) $000 —
Prescaler W (PSW) $00 —
Timer counter A (TCA) $00 —
Timer counter B (TCB) $00 —
Timer counter C (TCC) $00 —
Timer counter D (TCD) $00 —
(PC) $0000 Indicates program execution point from start
DCD1)
(DCD2) - - 00
(DCR0,
–DCR7)
(PMRC3,
PMRC1,
PMRC0)
(ESR1) 0000 Disables edge detection
(ESR2) 0000 Disables edge detection
Value Contents
address of ROM area
All bits 0 Turns output buffer off (to high impedance)
All bits 0
000 Refer to description of port mode register C
19
Page 22
HD404829R Series
Table 1 Initial Values After MCU Reset (cont)
Initial
Item Abbr.
Timer/
counters,
serial
interface
A/D A/D mode register (AMR) 00 - 0 Refer to description of A/D mode register
LCD LCD control register (LCR) - 000 Refer to description of LCD control register
Bit registers Low speed on flag (LSON) 0 Refer to description of operating modes
Others Miscellaneous register (MIS) 0000 Refer to description of operating modes, I/O, and
Timer write register B (TWBU,
TWBL)
Timer write register C (TWCU,
TWCL)
Timer write register D (TWDU,
TWDL)
Octal counter (OC) 000 —
A/D data register (ADRL,
ADRU)
LCD mode register (LMR) 0000 Refer to description of LCD duty-cycle/clock
LCD output register 1 (LOR1) 0000 Sets R-port/LCD segment pins to R port mode
LCD output register 2 (LOR2) 0000
LCD output register 3 (LOR3) - 000
Watchdog timer on flag (WDON) 0 Refer to description of timer C
A/D start flag (ADSF) 0 Refer to description of A/D converter
Direct transfer on flag (DTON) 0 Refer to description of operating modes
Input capture status flag (ICSF) 0 Refer to description of timer D
Input capture error flag (ICEF) 0 Refer to description of timer D
System clock select
register bits 2,1
Bank register (V) - - 00 Refer to description of RAM memory map
(SSR2,
SSR1)
Notes: 1. The statuses of other registers and flags after MCU reset are shown in the following table.
2. X indicates invalid value. – indicates that the bit does not exist.
Value Contents
$X0 —
$X0 —
$X0 —
$80 Refer to description of A/D data register
control register
serial interface
000 Refer to description of operating modes and
oscillation circuits
20
Page 23
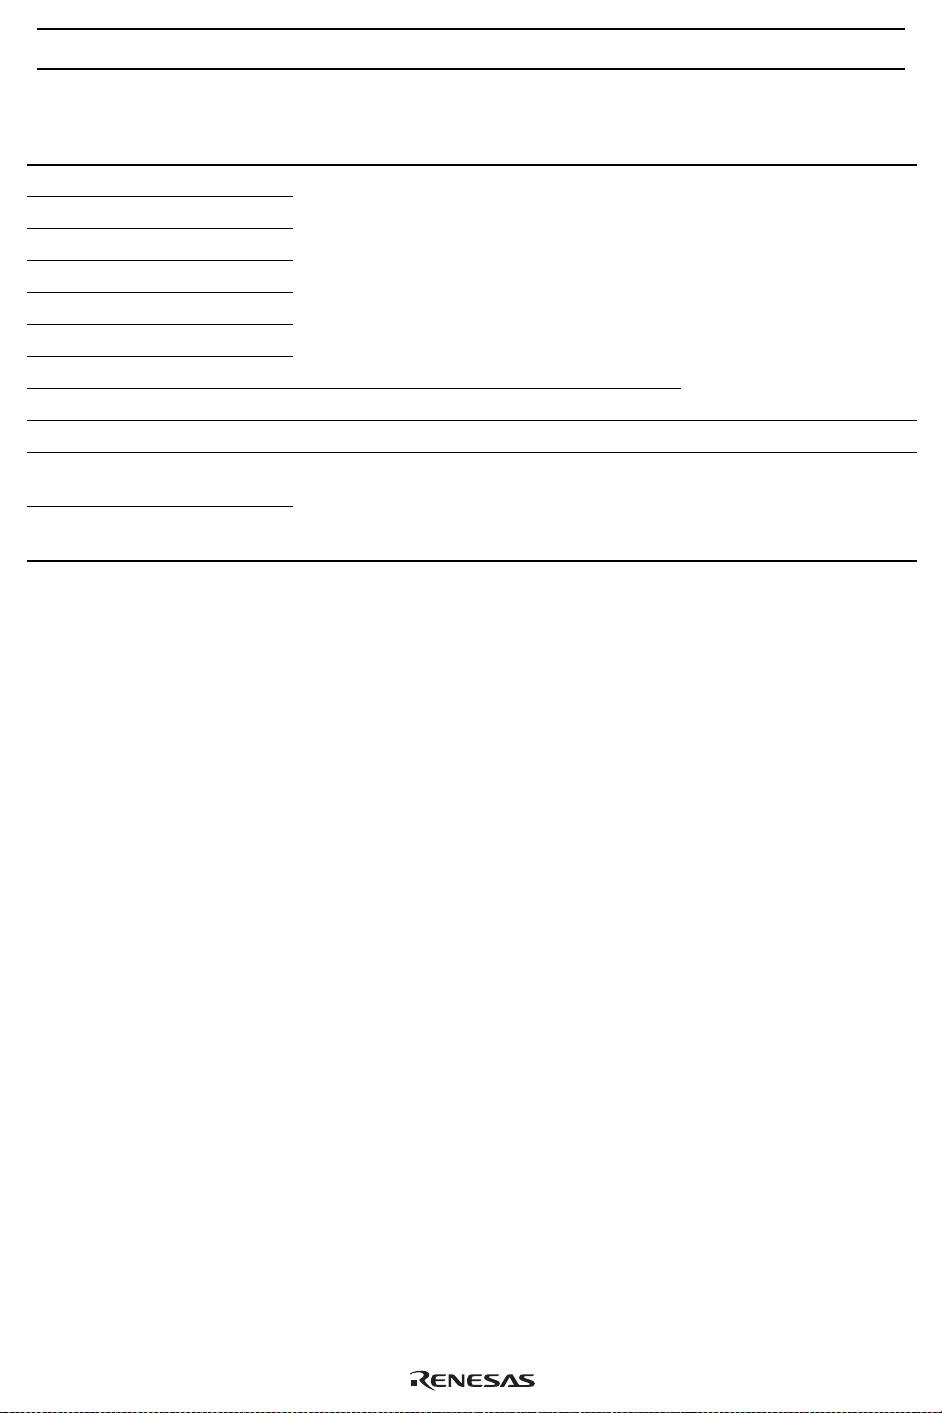
HD404829R Series
Status After Cancellation of Stop Mode by
Item Abbr.
Carry flag (CA) Pre-stop-mode values are not guaranteed; Pre-MCU-reset values
Accumulator (A) values must be initialized by program are not guaranteed; valB register (B) ues must be initialized by
W register (W) program
X/SPX register (X/SPX)
Y/SPY register (Y/SPY)
Serial data register (SRL, SRU)
RAM Pre-stop-mode values are retained
RAM enable flag (RAME) 1 0 0
Port mode
register C bit 2
System clock
select register bit 3
(PMRC2) Pre-stop-mode
(SSR3)
STOPC Input
values are retained
Status After Cancellation of Stop Mode by
RESET Input
00
Status After all Other Types
of Reset
Interrupts
The MCU has 11 interrupt sources: five external signals (INT0, INT1, INT2–INT4), four timer/ counters
(timers A, B, C, and D), serial interface, and A/D converter.
An interrupt request flag (IF), interrupt mask (IM), and vector address are provided for each interrupt
source, and an interrupt enable flag (IE) controls the entire interrupt process.
Some vector addresses are shared by two different interrupts. They are timer B and INT2, timer C and
INT3, timer D and INT4, and A/D converter and serial interface interrupts. So the type of request that has
occurred must be checked at the beginning of interrupt processing.
Interrupt Control Bits and Interrupt Processing: Locations $000 to $003 and $022 to $023 in RAM are
reserved for the interrupt control bits which can be accessed by RAM bit manipulation instructions.
The interrupt request flag (IF) cannot be set by software. MCU reset initializes the interrupt enable flag
(IE) and the IF to 0 and the interrupt mask (IM) to 1.
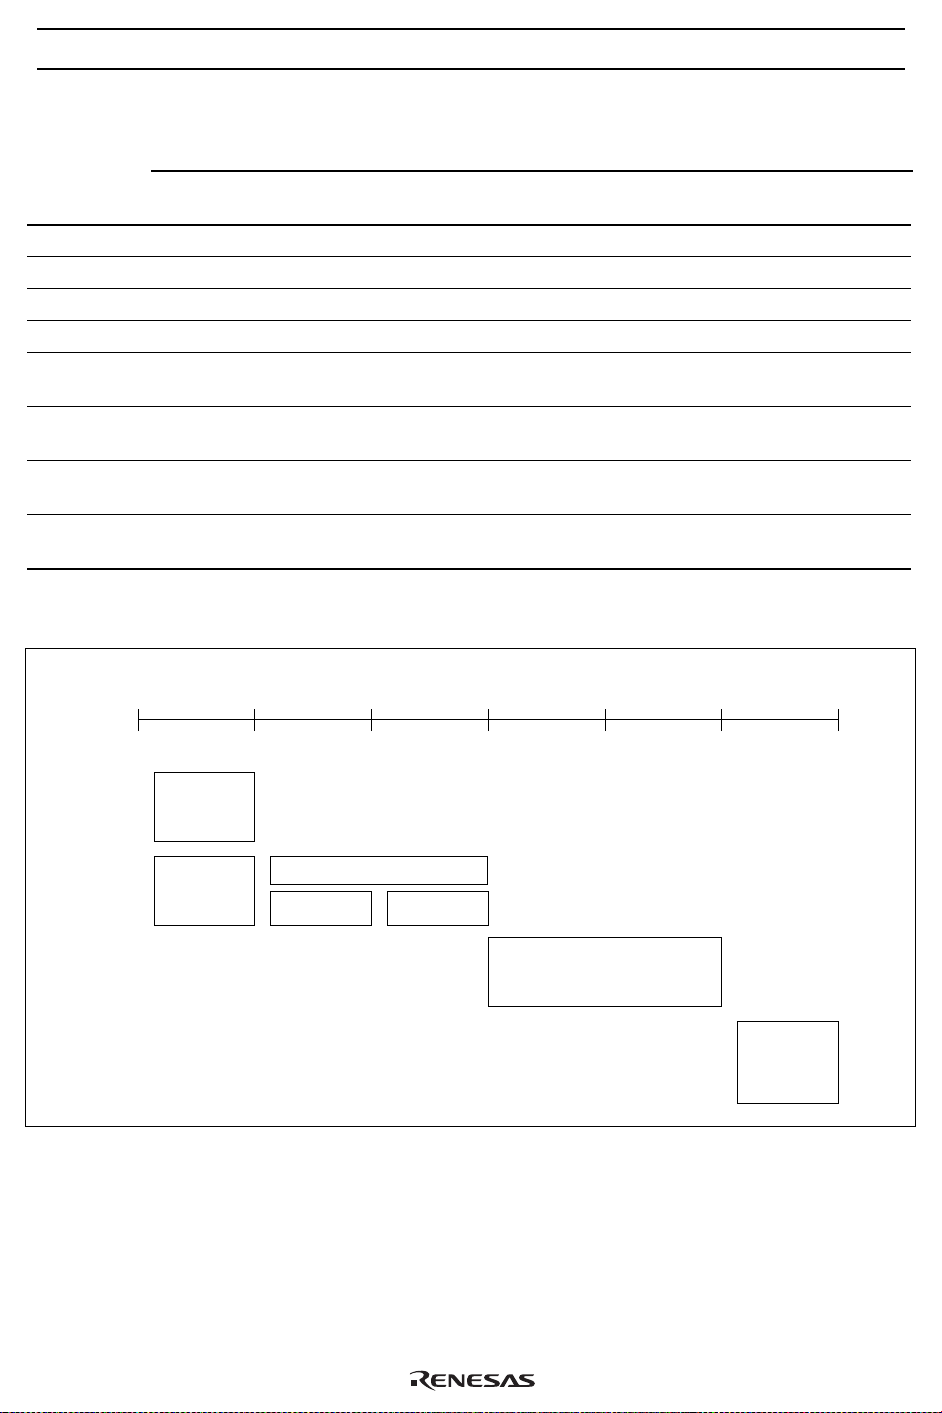
A block diagram of the interrupt control circuit is shown in figure 9, interrupt priorities and vector
addresses are listed in table 2, and interrupt processing conditions for the 11 interrupt sources are listed in
table 3.
An interrupt request occurs when the IF is set to 1 and the IM is set to 0. If the IE is 1 at that point, the
interrupt is processed. A priority programmable logic array (PLA) generates the vector address assigned to
that interrupt source.
The interrupt processing sequence is shown in figure 10 and an interrupt processing flowchart is shown in
figure 11. After an interrupt is acknowledged, the previous instruction is completed in the first cycle. The
IE is reset in the second cycle, the carry, status, and program counter values are pushed onto the stack
21
Page 24
HD404829R Series
during the second and third cycles, and the program jumps to the vector address to execute the instruction
in the third cycle.
Program the JMPL instruction at each vector address, to branch the program to the start address of the
interrupt program, and reset the IF by a software instruction within the interrupt program.
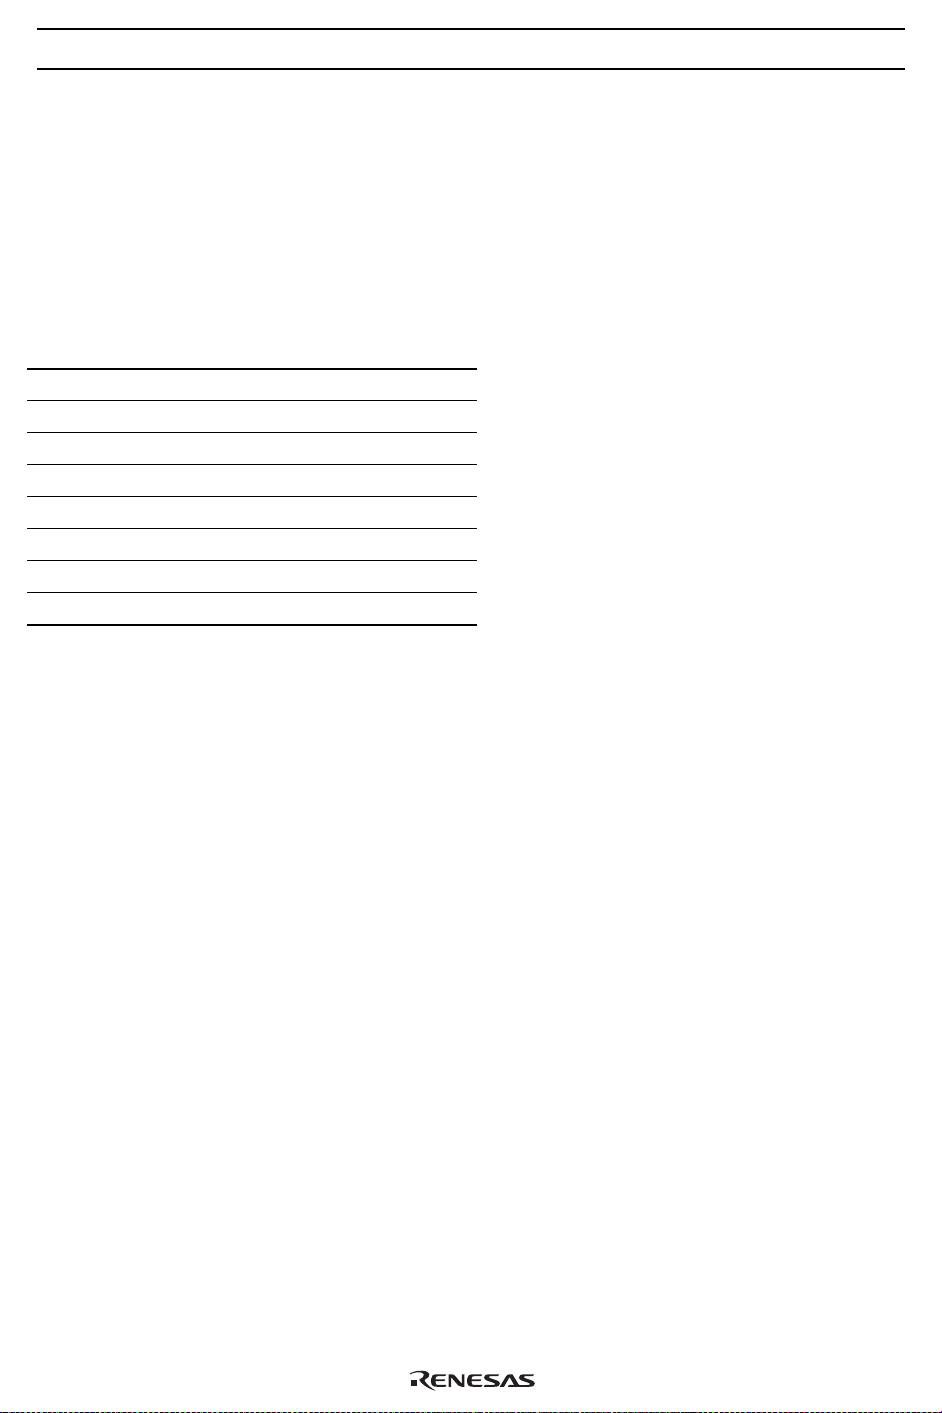
Table 2 Vector Addresses and Interrupt Priorities
Reset/Interrupt Priority Vector Address
RESET, STOPC* — $0000
INT
0
INT
1
Timer A 3 $0006
Timer B, INT2 4 $0008
Timer C, INT3 5 $000A
Timer D, INT4 6 $000C
A/D, Serial 7 $000E
Note: * The STOPC interrupt request is valid only in
stop mode.
1 $0002
2 $0004
22
Page 25
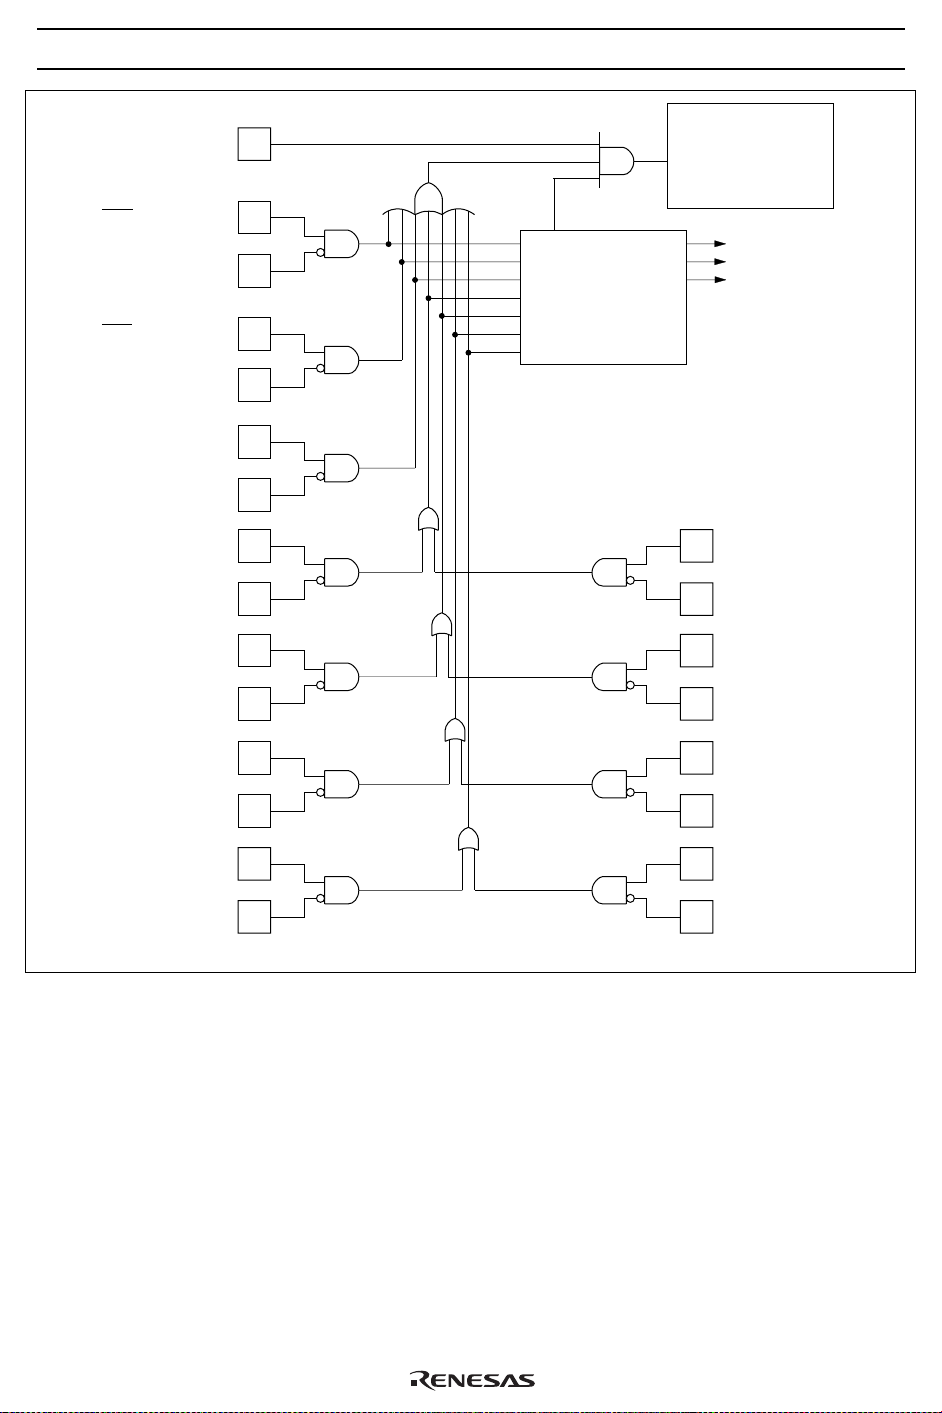
INT0 interrupt
interrupt
INT
1
Timer A interrupt
Timer B interrupt
Timer C interrupt
Timer D interrupt
A/D interrupt
$ 000,0
IE
$ 000,2
IFO
$ 000,3
IMO
$ 001,0
IF1
$ 001,1
IM1
$ 001,2
IFTA
$ 001,3
IMTA
$ 002,0
IFTB
$ 002,1
IMTB
$ 002,2
IFTC
$ 002,3
IMTC
$ 003,0
IFTD
$ 003,1
IMTD
$ 003,2
IFAD
$ 003,3
IMAD
Priority controller
HD404829R Series
Interrupt
request
Vector
address
$ 022,0
IF2
INT
interrupt
2
$ 022,1
IM2
$ 022,2
IF3
INT
interrupt
3
$ 022,3
IM3
$ 023,0
IF4
INT
interrupt
4
$ 023,1
IM4
$ 023,2
Serial interrupt
IFS
$ 023,3
IMS
Note: $m,n is RAM address $m, bit number n.
Figure 9 Interrupt Control Circuit
23
Page 26
HD404829R Series
Table 3 Interrupt Processing and Activation Conditions
Interrupt Source
Interrupt
Cuntrol Bit INT
Timer B or
0
INT
1
Timer A
INT
2
Timer C or
INT
3
IE 1111 1 1 1
IF0 . IM0 1000 0 0 0
IF1 . IM1 * 100 0 0 0
IFTA . IMTA **10000
IFTB . IMTB
.
IM2
+ IF2
IFTC . IMTC
.
IM3
+ IF3
IFTD . IMTD
.
IM4
+ IF4
IFAD . IMAD
.
IMS
+ IFS
***1000
**** 100
**** * 10
**** * * 1
Note: Bits marked * can be either 0 or 1. Their values have no effect on operation.
Timer D or
INT
4
A/D or
Serial
Instruction cycles
123456
Instruction
execution
Interrupt
acceptance
Note: *
*
Stacking
IE reset
The stack is accessed and the IE reset after the instruction
is executed, even if it is a 2-cycle instruction.
Vector address
generation
Execution of JMPL
instruction at vector address
Figure 10 Interrupt Processing Sequence
Execution of
instruction at
start address
of interrupt
routine
24
Page 27

Power on
HD404829R Series
RESET = 1?
Yes
Reset MCU
No
Interrupt
request?
No
Execute instruction
←
PC (PC) + 1
←
PC $0002
←
PC $0004
Yes
No
IE = 1?
Accept the interrupt
IE 0
Stack (PC)
Stack (CA)
Stack (ST)
Yes
interrupt?
Yes
interrupt?
INT
INT
Yes
←
←
←
←
0
No
1
←
PC $0006
←
PC $0008
←
PC $000A
←
PC $000C
←
PC $000E
Yes
Yes
Yes
Yes
(A/D, serial interrupt)
Figure 11 Interrupt Processing Flowchart
No
Timer-A
interrupt?
No
Timer-B/INT
interrupt?
No
Timer-C/INT
interrupt?
No
Timer-D/INT
interrupt?
No
2
3
4
25
Page 28

HD404829R Series
Interrupt Enable Flag (IE: $000, Bit 0): Controls the entire interrupt process. It is reset by the interrupt
processing and set by the RTNI instruction, as listed in table 4.
Table 4 Interrupt Enable Flag (IE: $000, Bit 0)
Interrupt
IE
0 Disabled
1 Enabled
External Interrupts (INT0, INT1, INT2–INT4): Five external interrupt signals.
External Interrupt Request Flags (IF0–IF4: $000, $001, $022, $023): IF0 and IF1 are set at the falling
edge of signals input to INT0 and INT1, and IF2–IF4 are set at the rising or falling edge of signals input to
INT2–INT4, as listed in table 5. The INT2–INT4 interrupt edges are selected by the detection edge select
registers (ESR1, ESR2: $026, $027) as shown in figures 12 and 13.
Table 5 External Interrupt Request Flags (IF0–IF4: $000, $001, $022, $023)
IF0–IF4 Interrupt Request
0No
1 Yes
Enabled/Disabled
Detection edge selection register 1 (ESR1: $026)
Bit
Initial value
Read/Write
Bit name
ESR13
0
1
Note: Both falling and rising edges are detected.
*
ESR13
ESR12
0
1
0
1
3
0
W
2
0
W
ESR12
INT
detection edge
3
No detection
Falling-edge detection
Rising-edge detection
Double-edge detection
1
0
W
ESR11
0
0
W
ESR10
**
Figure 12 Detection Edge Selection Register 1 (ESR1)
ESR11
0
1
ESR10
0
1
0
1
INT
detection edge
2
No detection
Falling-edge detection
Rising-edge detection
Double-edge detection
26
Page 29

Detection edge selection register 2 (ESR2: $027)
HD404829R Series
Bit
Initial value
Read/Write
Bit name
ESR23
0
1
Note: Both falling and rising edges are detected.
*
ESR23
ESR22
0
1
0
1
3
0
W
2
0
W
ESR22
EVND detection edge
No detection
Falling-edge detection
Rising-edge detection
Double-edge detection
1
0
W
ESR21
0
0
W
ESR20
ESR21
**
ESR20
0
1
0
1
0
1
INT
detection edge
4
No detection
Falling-edge detection
Rising-edge detection
Double-edge detection
Figure 13 Detection Edge Selection Register 2 (ESR2)
External Interrupt Masks (IM0–IM4: $000, $001, $022, $023): Prevent (mask) interrupt requests
caused by the corresponding external interrupt request flags, as listed in table 6.
Table 6 External Interrupt Masks (IM0–IM4: $000, $001, $022, $023)
IM0–IM4 Interrupt Request
0 Enabled
1 Disabled (masked)
Timer A Interrupt Request Flag (IFTA: $001, Bit 2): Set by overflow output from timer A, as listed in
table 7.
Table 7 Timer A Interrupt Request Flag (IFTA: $001, Bit 2)
IFTA–IFTD Interrupt Request
0No
1 Yes
27
Page 30
HD404829R Series
Timer A Interrupt Mask (IMTA: $001, Bit 3): Prevents (masks) an interrupt request caused by the
timer A interrupt request flag, as listed in table 8.
Table 8 Timer A Interrupt Mask (IMTA: $001, Bit 3)
IMTA–IMTD Interrupt Request
0 Enabled
1 Disabled (masked)
Timer B Interrupt Request Flag (IFTB: $002, Bit 0): Set by overflow output from timer B, as listed in
table 7.
Timer B Interrupt Mask (IMTB: $002, Bit 1): Prevents (masks) an interrupt request caused by the
timer B interrupt request flag, as listed in table 8.
Timer C Interrupt Request Flag (IFTC: $002, Bit 2): Set by overflow output from timer C, as listed in
table 7.
Timer C Interrupt Mask (IMTC: $002, Bit 3): Prevents (masks) an interrupt request caused by the
timer C interrupt request flag, as listed in table 8.
Timer D Interrupt Request Flag (IFTD: $003, Bit 0): Set by overflow output from timer D, or by the
rising or falling of signals input to EVND when the input capture function is used, as listed in table 7.
Timer D Interrupt Mask (IMTD: $003, Bit 1): Prevents (masks) an interrupt request caused by the
timer D interrupt request flag, as listed in table 8.
Serial Interrupt Request Flag (IFS: $023, Bit 2): Set when data transfer is completed or when data
transfer is suspended, as listed in table 9.
Table 9 Serial Interrupt Request Flag (IFS: $023, Bit 2)
IFS Interrupt Request
0No
1 Yes
28
Page 31
HD404829R Series
Serial Interrupt Mask (IMS: $023, Bit 3): Prevents (masks) an interrupt request caused by the serial
interrupt request flag, as listed in table 10.
Table 10 Serial Interrupt Mask (IMS: $023, Bit 3)
IMS Interrupt Request
0 Enabled
1 Disabled (masked)
A/D Interrupt Request Flag (IFAD: $003, Bit 2): Set at the completion of A/D conversion, as listed in
table 11.
Table 11 A/D Interrupt Request Flag (IFAD: $003, Bit 2)
IFAD Interrupt Request
0No
1 Yes
A/D Interrupt Mask (IMAD: $003, Bit 3): Prevents (masks) an interrupt request caused by the A/D
interrupt request flag, as listed in table 12.
Table 12 A/D Interrupt Mask (IMAD: $003, Bit 3)
IMAD Interrupt Request
0 Enabled
1 Disabled (masked)
29
Page 32
HD404829R Series
Operating Modes
The MCU has five operating modes as shown in table 13. The operations in each mode are listed in tables
14 and 15. Transitions between operating modes are shown in figure 14.
Active Mode: All MCU functions operate according to the clock generated by the system oscillator OSC
and OSC2.
Table 13 Operating Modes and Clock Status
Mode Name
Active Standby Stop Watch Subactive
Activation
method
Status System
oscillator
Subsystem
oscillator
Cancellation
method
RESET
cancellation,
interrupt
request,
STOPC
cancellation
in stop mode,
STOP/SBY
instruction in
subactive mode
(when direct
transfer is
selected)
Operating Operating Stopped Stopped Stopped
Operating *1 Operating *1 Operating *1 Operating *1 Operating *1
RESET input,
STOP/SBY
instruction
SBY
instruction
from active
mode
RESET input,
interrupt
request
STOP
instruction
when
TMA3 = 0
RESET input,
STOPC input
in stop mode
STOP
instruction
when
TMA3 = 1
or SBY
instruction from
subactive mode
(when LSON = 1,
or LSON and
DTON are
both 0)
RESET input,
INT0 or timer A
interrupt
request
AN interrupt
request from
timer A or
INT0 in watch
mode when
LSON = 1
RESET input,
STOP/SBY
instruction
Notes: 1. Operating or stopping the oscillator can be selected by setting bit 3 of the system clock select
register (SSR: $029).
2. Subactive mode is an optional function; specify it on the function option list.
*2
1
30
Page 33

Table 14 Operations in Low-Power Dissipation Modes
HD404829R Series
Function Stop Mode Watch Mode Standby Mode Subactive Mode
CPU Reset Retained Retained Operating
RAM Retained Retained Retained Operating
Timer A Reset Operating Operating Operating
Timer B Reset Stopped Operating Operating
Timer C Reset Stopped Operating Operating
Timer D Reset Stopped Operating Operating
Serial interface Reset Stopped
*3
Operating Operating
A/D Reset Stopped Operating Stopped
LCD Reset Operating
I/O Reset
*1
Retained Retained Operating
*4
Operating Operating
Notes: 1. Output pins are at high impedance.
2. Subactive mode is an optional function specified on the function option list.
3. Transmission/Reception is activated if a clock is input in external clock mode. However,
interrupts stop.
4. When a 32-kHz clock source is used.
Table 15 I/O Status in Low-Power Dissipation Modes
*2
Standby Mode,
Watch Mode Stop Mode
D0–D
D10–D
9
11
Retained High impedance Input enabled
— — Input enabled
R0–R7 Retained or output
of peripheral functions
Output Input
Active Mode,
Subactive Mode
High impedance Input enabled
31
Page 34

HD404829R Series
Standby mode
:
CPU
CLK
PER
:
:
:
:
Oscillate
Oscillate
Stop
f
cyc
f
cyc
f
OSC
f
X
ø
ø
ø
SBY
Interrupt
Reset by
RESET input or
by watchdog timer
RAME = 0 RAME = 1
RESET1 RESET2
Active
mode
OSC
:
X
CPU
CLK
PER
:
:
:
:
Oscillate
Oscillate
f
cyc
f
cyc
f
cyc
(TMA3 = 0)
f
f
ø
ø
ø
STOPC
STOPC
STOP
STOP
Stop mode
(TMA3 = 0, SSR3 = 0)
:
CPU
CLK
PER
:
CPU
CLK
PER
:
:
:
:
:
:
:
:
Stop
Oscillate
Stop
Stop
Stop
Stop
Stop
Stop
Stop
Stop
f
OSC
f
X
ø
ø
ø
(TMA3 = 0, SSR3 = 1)
f
OSC
f
X
ø
ø
ø
Watch mode
f
:
OSC
f
:
X
f
:
cyc
f
:
SUB
f
:
W
ø
CPU
ø
CLK
ø
PER
LSON:
DTON:
:
CPU
CLK
PER
:
:
:
:
Oscillate
Oscillate
Stop
f
W
f
cyc
f
OSC
f
X
ø
ø
ø
Main oscillation frequency
Suboscillation frequency
for time-base
f
/4
OSC
f
/8 or fX/4
X
(software selectable)
f
/8
X
CPU operating clock
:
Timer A operating clock
:
Clock for peripheral functions
:
(except timer A)
Low speed on flag
Direct transfer on flag
(TMA3 = 1) (TMA3 = 1, LSON = 0)
SBY
Interrupt
f
f
ø
ø
ø
OSC
:
X
CPU
CLK
PER
:
:
:
:
Oscillate
Oscillate
f
cyc
f
W
f
cyc
*2
Subactive
mode
f
f
ø
ø
ø
Notes:
Stop
:
OSC
Oscillate
:
X
f
:
CPU
CLK
PER
SUB
:
f
W
:
f
SUB
1. Interrupt source
2. STOP/SBY (DTON = 1, LSON = 0)
3. STOP/SBY (DTON = 0, LSON = 0)
4. STOP/SBY (DTON = Don’t care, LSON = 1)
Figure 14 MCU Status Transitions
STOP
INT
,
0
timer A
*4
INT
,
0
timer A
*
1
*3
STOP
*1
f
OSC
f
X
ø
ø
ø
(TMA3 = 1, LSON = 1)
f
OSC
f
X
ø
ø
ø
:
CPU
CLK
PER
:
CPU
CLK
PER
:
:
:
:
:
:
:
:
Stop
Oscillate
Stop
f
W
Stop
Stop
Oscillate
Stop
f
W
Stop
32
Page 35
HD404829R Series
Standby Mode: In standby mode, the oscillators continue to operate, but the clocks related to instruction
execution stop. Therefore, the CPU operation stops, but all RAM and register contents are retained, and the
D or R port status, when set to output, is maintained. Peripheral functions such as interrupts, timers, and
serial interface continue to operate. The power dissipation in this mode is lower than in active mode
because the CPU stops.
The MCU enters standby mode when the SBY instruction is executed in active mode.
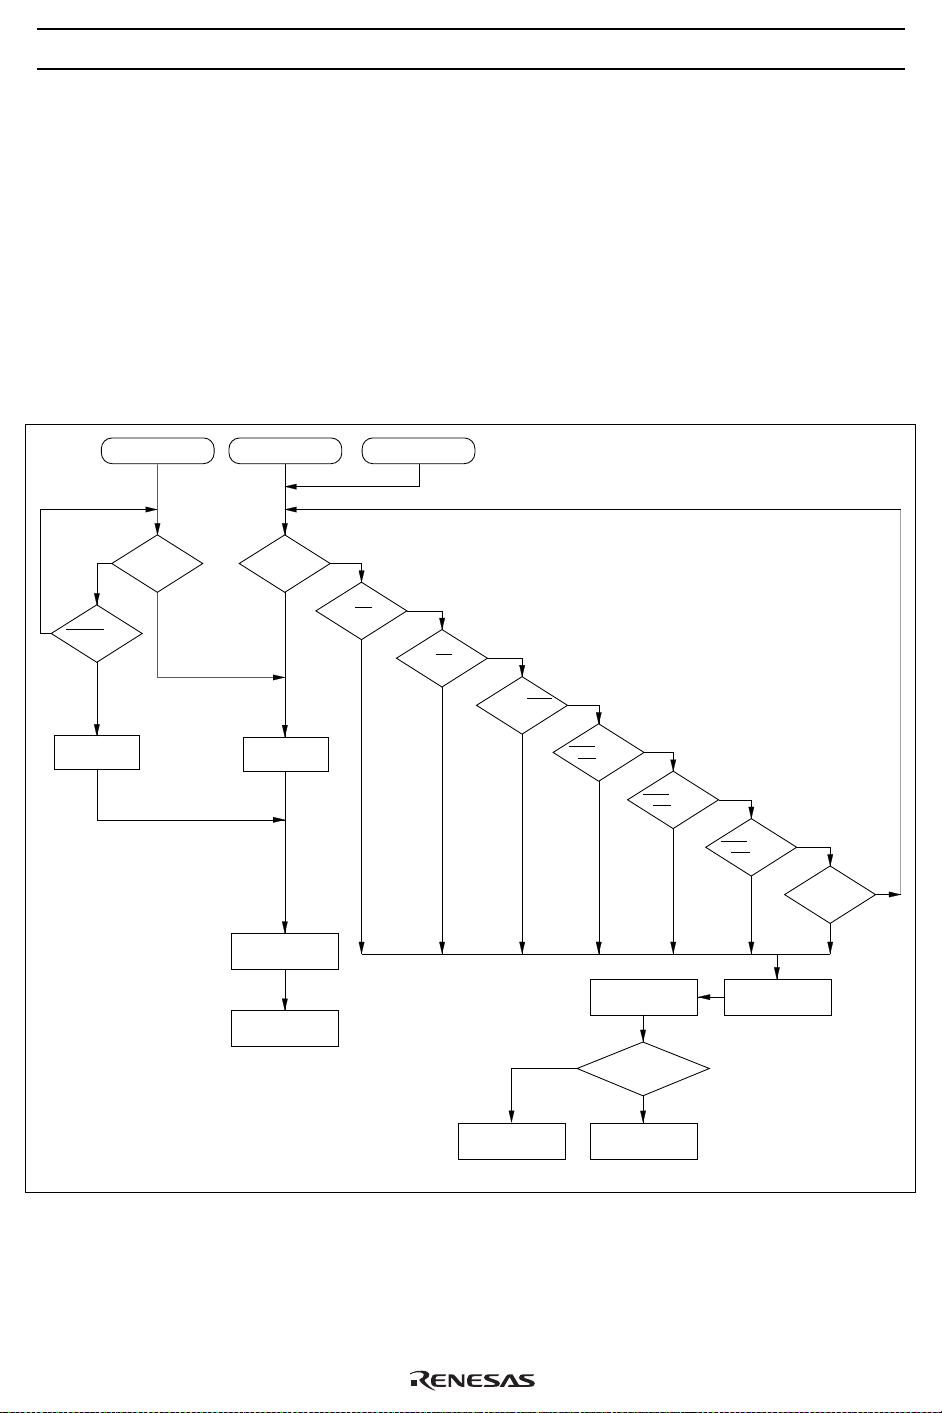
Standby mode is terminated by a RESET input or an interrupt request. If it is terminated by RESET input,
the MCU is reset as well. After an interrupt request, the MCU enters active mode and executes the next
instruction after the SBY instruction. If the interrupt enable flag is 1, the interrupt is then processed; if it is
0, the interrupt request is left pending and normal instruction execution continues. A flowchart of
operation in standby mode is shown in figure 15.
Standby mode
RESET = 1?
Yes
RAME = 0
System clock
oscillator started
System reset
No
IF0 • IM0 = 1?
Yes
No
STOPC = 0?
RAME = 1
Stop mode
No
Yes
RESET = 1?
Yes
Notes: 1. Only when clearing from standby mode
2. IFAD • IMAD + IFS • IMS = 1
Watch mode
No
IF1 • IM1 = 1?
No
*1
Yes
IFTA • IMTA
Next instruction
execution
= 1?
Yes
No
IFTB •
IMTB + IF2 •
IM2 = 1?
No
No
*1
IFTC •
Yes
IMTC + IF3 •
IM3 = 1?
Next instruction
execution
IF = 1,
IM = 0,
IE = 1?
Yes
Interrupts
enabled
Yes
*1
No
IFTD •
IMTD + IF4 •
IM4 = 1?
*1
Yes
System clock
oscillator started
No
No
*2
*1
Yes
Figure 15 MCU Operation Flowchart
33
Page 36

HD404829R Series
Stop Mode: In stop mode, all MCU operations stop and RAM data is retained. Therefore, the power
dissipation in this mode is the least of all modes. The OSC1 and OSC2 oscillator stops. For the X1 and X2
oscillator to operate or stop can be selected by setting bit 3 of the system clock select register (SSR: $029;
operating: SSR3 = 0, stop: SSR3 = 1) (figure 27). The MCU enters stop mode if the STOP instruction is
executed in active mode when bit 3 of timer mode register A (TMA: $008) is set to 0 (TMA3 = 0) (figure
44).
Stop mode is terminated by a RESET input or a STOPC input as shown in figure 16. RESET or STOPC
must be applied for at least one tRC to stabilize oscillation (refer to the AC Characteristics section). When
the MCU restarts after stop mode is cancelled, all RAM contents before entering stop mode are retained,
but the accuracy of the contents of the accumulator, B register, W register, X/SPX register, Y/SPY register,
carry flag, and serial data register cannot be guaranteed.
Stop mode
Oscillator
Internal
clock
RESET
STOPC
t
res
STOP instruction execution
(at least equal to oscillator stabilization time t
RC
)
Figure 16 Timing of Stop Mode Cancellation
Watch Mode: In watch mode, the clock function (timer A) using the X1 and X2 oscillator and the LCD
function operate, but other function operations stop. Therefore, the power dissipation in this mode is the
second least to stop mode, and this mode is convenient when only clock display is used. In this mode, the
OSC1 and OSC2 oscillator stops, but the X1 and X2 oscillator operates. The MCU enters watch mode if
the STOP instruction is executed in active mode when TMA3 = 1, or if the STOP or SBY instruction is
executed in subactive mode.
Watch mode is terminated by a RESET input or a timer-A/INT0 interrupt request. For details of RESET
input, refer to the Stop Mode section. When terminated by a timer-A/INT0 interrupt request, the MCU
enters active mode if LSON = 0, or subactive mode if LSON = 1. After an interrupt request is generated,
the time required to enter active mode is tRC for a timer A interrupt, and TX (where T + tRC < TX < 2T +
tRC) for an INT0 interrupt, as shown in figures 17 and 18.
Operation during mode transition is the same as that at standby mode cancellation (figure 15).
34
Page 37
HD404829R Series
Subactive Mode: The OSC1 and OSC2 oscillator stops and the MCU operates with a clock generated by
the X1 and X2 oscillator. In this mode, functions except the A/D conversion operate. However, because
the operating clock is slow, the power dissipation becomes low, next to watch mode.
The CPU instruction execution speed can be selected as 244 µs or 122 µs by setting bit 2 (SSR2) of the
system clock select register (SSR: $029). Note that the SSR2 value must be changed in active mode. If the
value is changed in subactive mode, the MCU may malfunction.
When the STOP or SBY instruction is executed in subactive mode, the MCU enters either watch or active
mode, depending on the statuses of the low speed on flag (LSON: $020, bit 0) and the direct transfer on
flag (DTON: $020, bit 3).
Subactive mode is an optional function that the user must specify on the function option list.
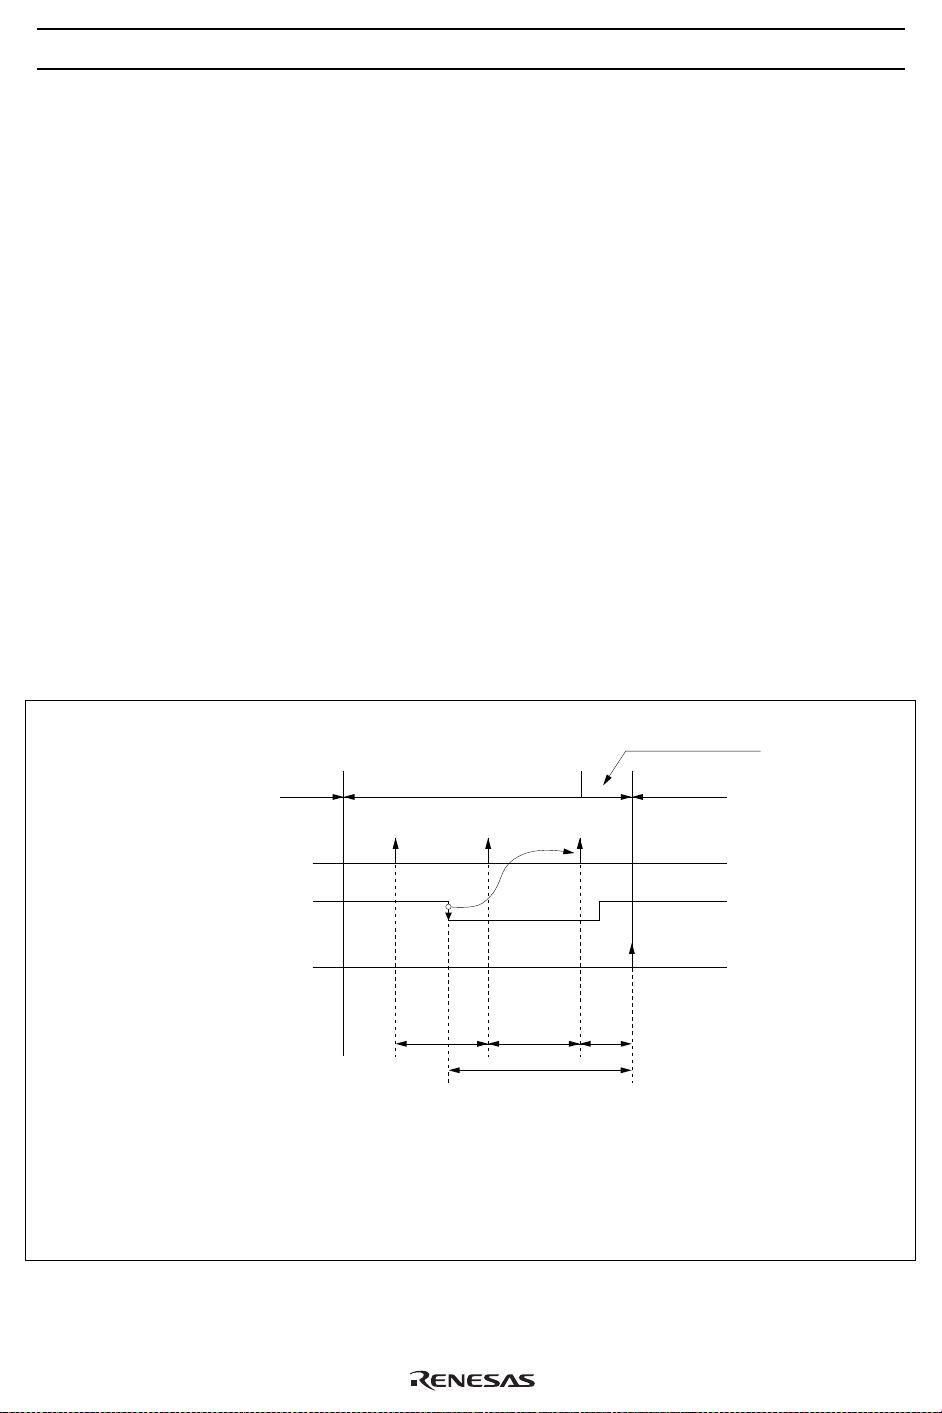
Interrupt Frame: In watch and subactive modes, φ
is applied to timer A and the INT
CLK
Icircuit.
0
Prescaler W and timer A operate as the time-base and generate the timing clock for the interrupt frame.
Three interrupt frame lengths (T) can be selected by setting the miscellaneous register (MIS: $00C) (figure
18).
In watch and subactive modes, the timer-A/ INT0 interrupt is generated synchronously with the interrupt
frame. The interrupt request is generated synchronously with the interrupt strobe timing except during
transition to active mode. The falling edge of the INT0 signal is input asynchronously with the interrupt
frame timing, but it is regarded as input synchronously with the second interrupt strobe clock after the
falling edge. An overflow and interrupt request in timer A is generated synchronously with the interrupt
strobe timing.
Oscillation
stabilization period
Active mode Watch mode Active mode
Interrupt strobe
INT
0
Interrupt request
generation
t
(During the transition
from watch mode to
active mode only)
T:
Interrupt frame length
t :
Oscillation stabilization period
RC
If the time from the fall of the INT
Note:
and active mode is entered and is designated Tx, then Tx will be in the
following range:
T + t
≤ Tx ≤ 2T + tRC
RC
signal until the interrrupt is accepted
0
TT
T
X
RC
Figure 17 Interrupt Frame
35
Page 38
HD404829R Series
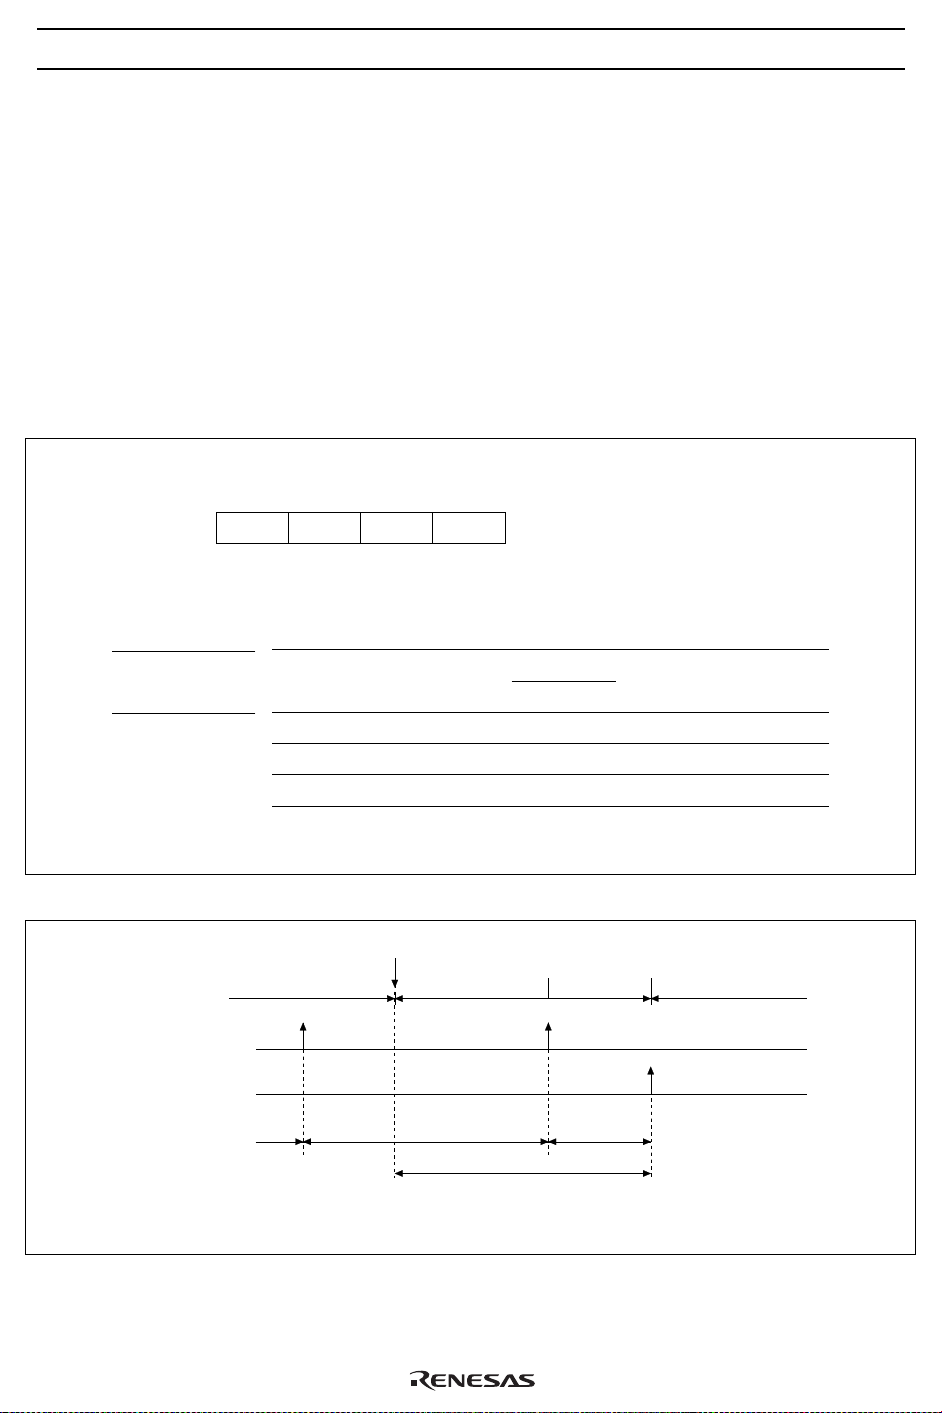
Direct Transition from Subactive Mode to Active Mode: Available by controlling the direct transfer on
flag (DTON: $020, bit 3) and the low speed on flag (LSON: $020, bit 0). The procedures are described
below:
• Set LSON to 0 and DTON to 1 in subactive mode.
• Execute the STOP or SBY instruction.
• The MCU automatically enters active mode from subactive mode after waiting for the MCU internal
processing time and oscillation stabilization time (figure 19).
Notes: 1. The DTON flag can be set only in subactive mode. It is always reset in active mode.
2. The transition time (TD) from subactive mode to active mode:
tRC < TD < T + t
Miscellaneous register (MIS: $00C)
RC
Bit
Initial value
Read/Write
Bit name
MIS3 MIS2
Buffer control.
Refer to figure 41.
Notes: 1.
Values of T and t
2.
The value is applied only when direct transfer operation is used.
(Set LSON = 0, DTON = 1)
Interrupt strobe
3
0
W
MIS3
2
0
W
MIS2
MIS10MIS0 T
0
1
1
RC
MIS1
0 0.24414 ms
1
0
1
when a 32.768-kHz crystal oscillator is used to pins ×1 and ×2.
Figure 18 Miscellaneous Register (MIS)
STOP/SBY instruction execution
Subactive mode
1
0
W
MIS0
15.625 ms
62.5 ms
Not used
MCU internal
processing time
0
0
W
*
1 * 1
0.12207 ms
0.24414 ms
7.8125 ms
31.25 ms
Not used
t
RC
*2
Oscillation
stabilization
time
Oscillation circuit conditions
External clock input
Ceramic oscillator
Crystal oscillator
—
Active mode
36
Direct transfer
completion timing
T
Interrupt frame length
T:
Oscillation stabilization period
t :
RC
Direct transition time
T :
D
T
D
t
RC
Figure 19 Direct Transition Timing
Page 39
HD404829R Series
Stop Mode Cancellation by STOPC : The MCU enters active mode from stop mode by inputting
STOPC as well as by RESET. In either case, the MCU starts instruction execution from the starting
address (address 0) of the program. However, the value of the RAM enable flag (RAME: $021, bit 3)
differs between cancellation by STOPC and by RESET. When stop mode is cancelled by RESET, RAME
= 0; when cancelled by STOPC, RAME = 1. RESET can cancel all modes, but STOPC is valid only in
stop mode; STOPC input is ignored in other modes. Therefore, when the program requires to confirm that
stop mode has been cancelled by STOPC (for example, when the RAM contents before entering stop mode
is used after transition to active mode), execute the TEST instruction to the RAM enable flag (RAME) at
the beginning of the program.
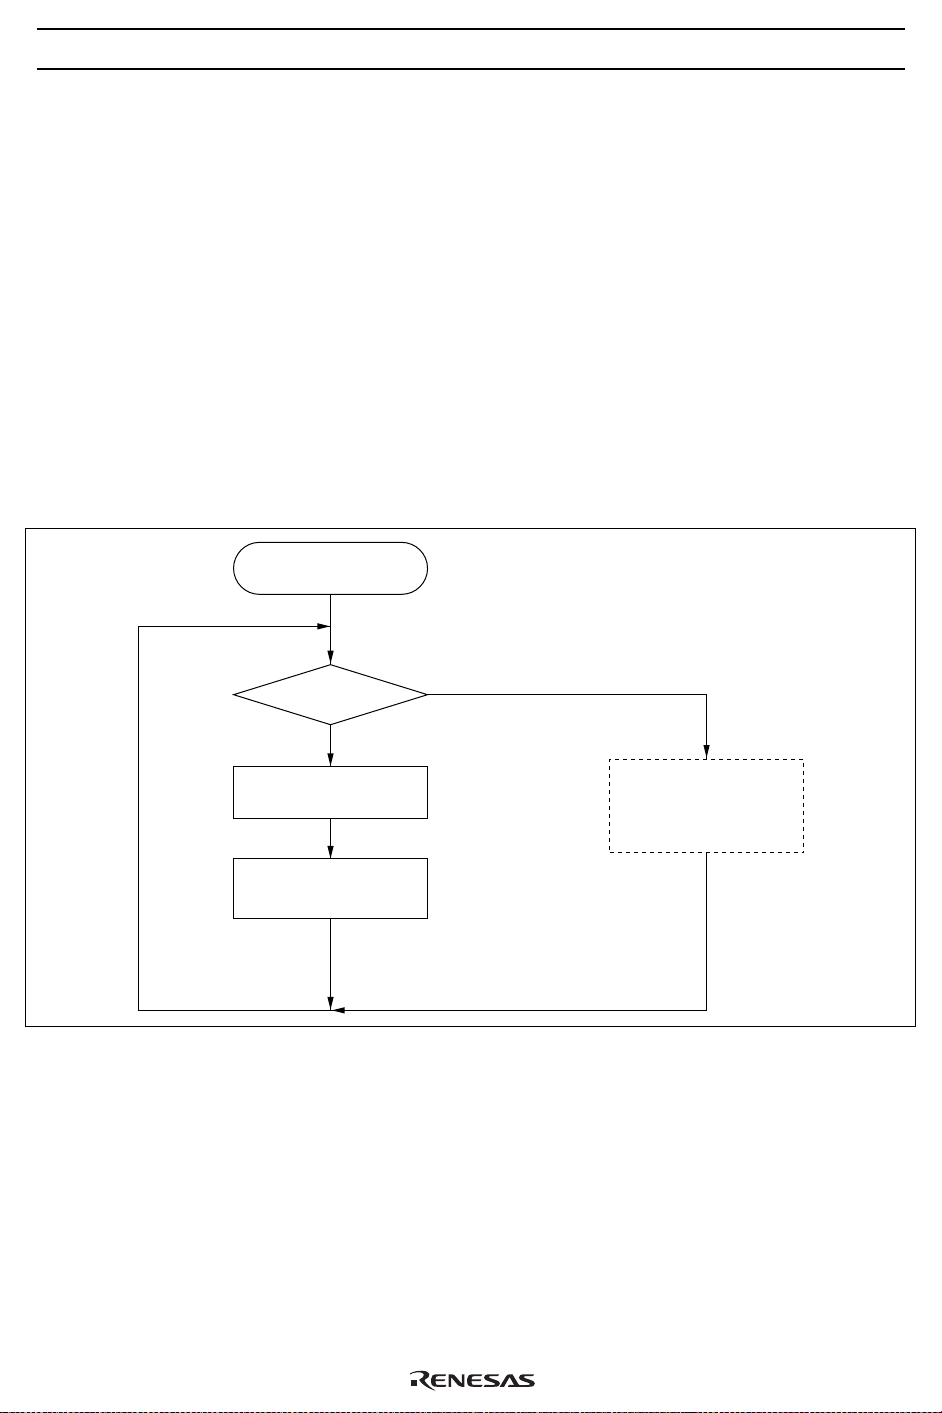
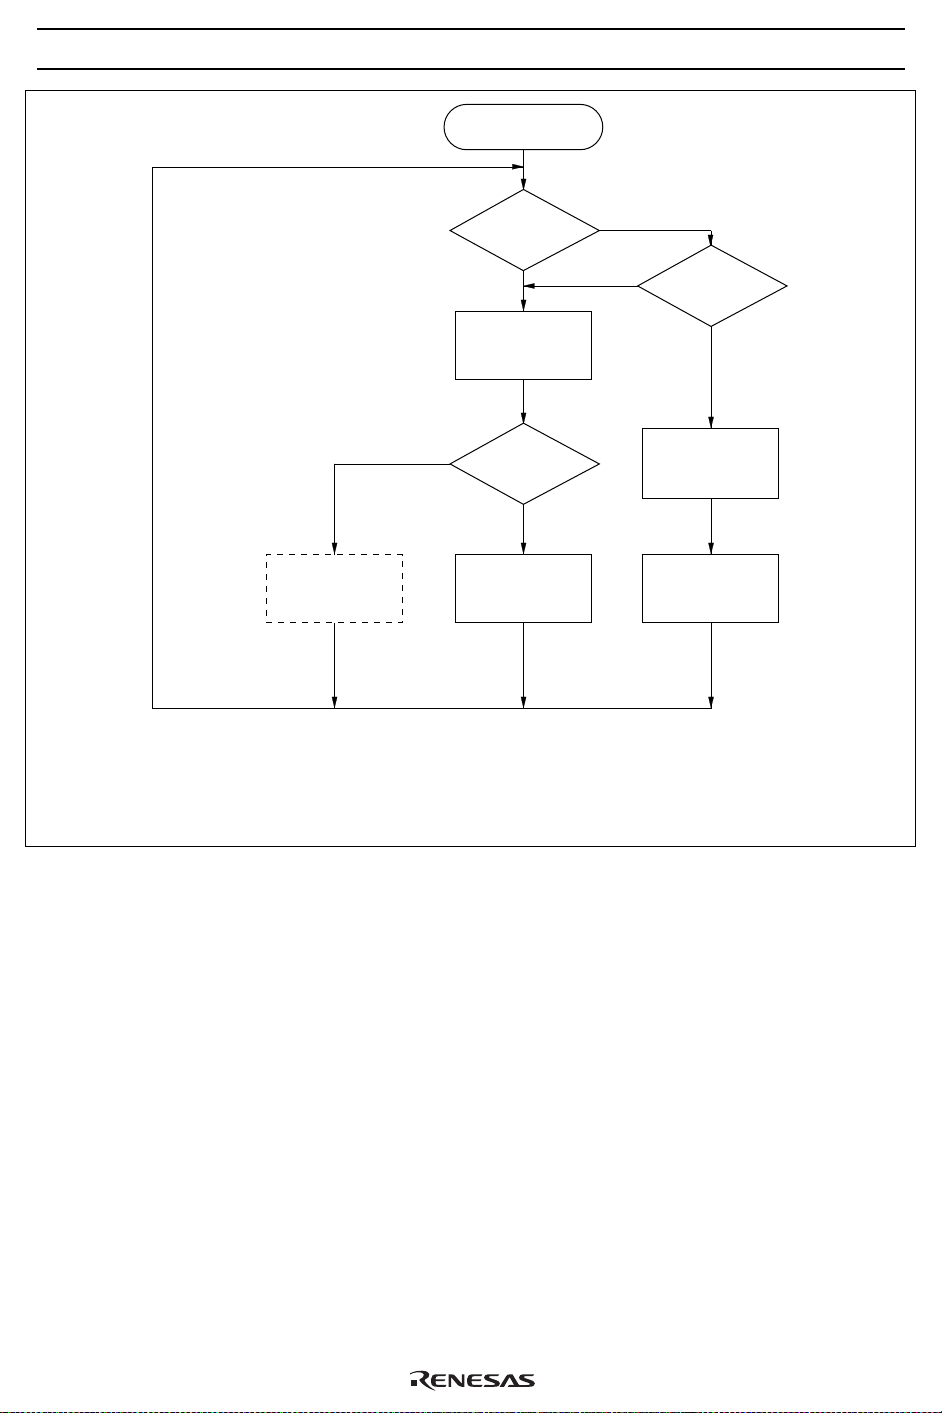
MCU Operation Sequence: The MCU operates in the sequence shown in figures 20 to 22. It is reset by
an asynchronous RESET input, regardless of its status.
The low-power mode operation sequence is shown in figure 22. With the IE flag cleared and an interrupt
flag set together with its interrupt mask cleared, if a STOP/SBY instruction is executed, the instruction is
cancelled (regarded as an NOP) and the following instruction is executed. Before executing a STOP/SBY
instruction, make sure all interrupt flags are cleared or all interrupts are masked.
Power on
RESET = 1 ?
Yes
RAME = 0
Reset MCU
No
Figure 20 MCU Operating Sequence (Power On)
MCU
operation
cycle
37
Page 40
HD404829R Series
MCU operation
cycle
IF:
Interrupt request flag
IM:
Interrupt mask
IE:
Interrupt enable flag
PC:
Program counter
CA:
Carry flag
ST:
Status flag
Low-power mode
operation cycle
Yes
IF = 1?
No
Instruction
execution
SBY/STOP
instruction?
No
←
PC Next
location
Yes
No
IM = 0 and
IE = 1?
Yes
←
IE 0
Stack (PC),
←
(CA),
(ST)
←
PC Vector
address
38
Figure 21 MCU Operating Sequence (MCU Operation Cycle)
Page 41

STOP/SBY
Instruction
HD404829R Series
Interrupt
service
routine
No
IF = 1 and
IM = 0?
Yes
IE = 0
Yes
Hardware NOP
execution
PC ← (PC)+1
No
No
Standby/watch
mode
*
IF = 1 and
IM = 0?
Yes
Hardware NOP
execution
PC ← (PC)+1
Instruction
execution
No
Stop mode
STOPC = 0?
Yes
RAME = 1
Reset MCU
MCU operation
cycle
*Refer to figure 15, Flowchart for Exiting Low Power Modes, for IF and IM operation.
Note:
Figure 22 MCU Operating Sequence (Low-Power Mode Operation)
39
Page 42

HD404829R Series
Notes: 1. When watch mode or subactive mode on HD404829R Series/HD4074829 is used and the LCD
function is off in that mode, the watch mode or subactive mode current is larger, and
consequently the following settings should be made.
Perform the following writes in the order shown before the transition to watch mode (before
execution of the STOP instruction):
Write $0 to LCR
Write $3 to LMR
Also, when returning to active mode from watch mode or subactive mode, perform the following
writes in the order shown:
Write a value appropriate to the conditions of use to LMR
Write a value appropriate to the conditions of use to LCR
A sample programming flowchart for the above procedures is shown in figure 23.
.
.
.
LMR
LCR
.
.
.
Set
appropriate
values for
active mode
Initialization routine
.
.
.
LCR = $0
LMR = $3
.
.
.
STOP instruction
After the MCU enters active mode again
.
.
.
LMR
LCR
.
.
.
Include these
operations
Watch mode
Set
appropriate
values for
active mode
Main routine
Or transition to
subactive mode
INT or timer A
0
interrupt processing
routine
Figure 23 Programming Flowchart (LCD Display Off in Watch or Subactive Mode)
40
Page 43

HD404829R Series
Notes: 2. When the MCU is in watch mode or subactive mode, if the high level period before the falling
edge of I NT 0 is shorter than the interrupt frame, I NT 0 is not detected. Also, if the low level period
after the falling edge of I NT 0 is shorter than the interrupt frame, I NT 0 is not detected.
Edge detection is shown in figure 24. The level of the INT0 signal is sampled by a sampling
clock. When this sampled value changes to low from high, a falling edge is detected.
In figure 25, the level of the I NT 0 signal is sampled by an interrupt frame. In (a) the sampled
value is low at point A, and also low at point B. Therefore, a falling edge is not detected. In (b),
the sampled value is high at point A, and also high at point B. A falling edge is not detected in
this case either.
When the MCU is in watch mode or subactive mode, keep the high level and low level period of
INT0 longer than interrupt frame.
INT
0
Sampling
INT
0
Interrupt
frame
High Low
Low
Figure 24 Edge Detection
INT
0
Interrupt
A: Low B: Low
(a) High level period (b) Low level period
frame
A: High B: High
Figure 25 Sampling Example
41
Page 44

HD404829R Series
Internal Oscillator Circuit
A block diagram of the clock generation circuit is shown in figure 26. As shown in table 16, a ceramic
oscillator can be connected to OSC1 and OSC2, and a 32.768-kHz oscillator can be connected to X1 and
X2. The system oscillator can also be operated by an external clock. Bit 1 (SSR1) of the system clock
select register (SSR: $029) must be set according to the frequency of the oscillator connected to OSC1 and
OSC2 (figure 27).
Note: If the system clock select register (SSR: $029) setting does not match the oscillator frequency,
DTMF generator and subsystems using the 32.768-kHz oscillation will malfunction.
LSON
OSC
OSC
X1
X2
f
2
1
System
clock
oscillator
Sub-
system
clock
oscillator
OSC
f
X
division
circuit
1/8 or 1/4
division
circuit
division
circuit
1/4
1/8
f
cyc
t
cyc
f
SUB
t
subcyc
f
W
t
Wcyc
Timing
generation
circuit
Timing
generation
circuit
Timing
generation
circuit
System
clock
selection
circuit
ø
ø
CPU
PER
TMA3 bit
Clock
Time-base
selection
circuit
Note: **1/8 or 1/4 division ratio can be selected by setting bit 2 of the system
clock select register (SSR: $029).
Figure 26 Clock Generation Circuit
clock
CPU with ROM,
RAM, registers,
flags, and I/O
peripheral
(other than timer A)
ø
CLK
interrupt
Internal
module
interrupt
Time A
42
Page 45
System clock select register (SSR: $029)
HD404829R Series
SSR3
0
1
Bit
Initial value
Read/Write
Bit name
32-kHz oscillation stop
Oscillation operates in stop mode
Oscillation stops in stop mode
3
0
W
SSR3
2
0
W
SSR2
—
—
—
1
0
—
—
—
SSR1
0
1
32-kHz oscillation division
SSR2
0
1
Note:
ratio selection
f
= fX/8
SUB
f
= fX/4
SUB
SSR3 is cleared only by a RESET input. SSR3 will not be cleared
by a STOPC input duringstop mode, and will retain its value.
SSR3 will also not be cleared upon entering stop mode.
Figure 27 System Clock Select Register (SSR)
System clock selection
f
= 400 kHz to 1 MHz
OSC
f
= 1.6 to 4.2 MHz
OSC
D
0
GND
X2
X1
RESET
OSC
2
OSC
1
TEST
GND
AV
SS
Figure 28 Typical Layouts of Crystal and Ceramic Oscillator
43
Page 46

HD404829R Series
Table 16 Oscillator Circuit Examples
Circuit Configuration Circuit Constants
External clock
operation
External
oscillator
OSC
—
1
Ceramic oscillator
, OSC2)
(OSC
1
Crystal oscillator
, OSC2)
(OSC
1
Open
GND
GND
C
Ceramic
oscillator
C
C
1
Crystal
oscillator
C
2
OSC
2
Ceramic oscillator: CSB400P22 (Murata)
CSB400P (Murata)
R
= 1 MΩ ± 20%
f
C1 = C2 = 220 pF ± 5%
1
OSC
1
R
f
OSC
2
2
Ceramic oscillator: CSB800J122 (Murata)
CSB800J (Murata)
R
= 1 MΩ ± 20%
f
C
= C2 = 220 pF ± 5%
1
Ceramic oscillator: CSA2.00MG (Murata)
Rf = 1 MΩ ± 20%
C
= C2 = 30 pF ± 20%
1
Ceramic oscillator: CSA4.00MG (Murata)
Rf = 1 MΩ ± 20%
C
= C2 = 30 pF ± 20%
1
Rf = 1 MΩ ± 20%
OSC
OSC
1
2
R
f
C
= C2 = 10 to 22pF ± 20%
1
Crystal : Equivalent circuit at left
C
=7pF max
0
R
= 100Ω max
s
Crystal oscillator
(X1, X2)
44
OSC
1
C
LSC
1
R
S
C
0
X1
Crystal
oscillator
X2
C
2
GND
LSC
R
S
X1 X2
C
0
OSC
2
Crystal oscillator: 32.768 kHz: MX38T
(Nippon Denpa)
C
= C2 = 20 pF ± 20%
1
R
: 14 kΩ
S
C
: 1.5 pF
0
Page 47

HD404829R Series
Notes: 1. Circuit constants differ by the different types of crystal oscillators, ceramic oscillators, and with the
stray capacitance of the board, so consult the manufacturer of the oscillator to determine the
circuit parameters.
2. The wiring between the OSC
as possible, and must not cross other wiring. Refer to figure 28.
3. If not using a 32.768-kHz crystal oscillator, fix the X1 pin to V
, OSC2 (X1 and X2 pins), and the other elements should be as short
1
and leave the X2 pin open.
CC
45
Page 48
HD404829R Series
Input/Output
The MCU has 42 input/output pins (D0–D9, R00–R73) and 2 input pins (D10, D11). The features are
described below.
• Ten pins (D0–D9) are high-current input/output pins.
• The D10 and D11, and R00–R73 input/output pins are multiplexed with peripheral function pins such as
for the timers or serial interface. For these pins, the peripheral function setting is done prior to the D or
R port setting. Therefore, when a peripheral function is selected for a pin, the pin function and
input/output selection are automatically switched according to the setting.
• Input or output selection for input/output pins and port or peripheral function selection for multiplexed
pins are set by software.
• Peripheral function output pins are CMOS output pins. Only the R23/SO pin can be set to NMOS open-
drain output by software.
• In stop mode, the MCU is reset, and therefore peripheral function selection is cancelled. Input/output
pins are in high-impedance state.
• Each input/output pin has a built-in pull-up MOS, which can be individually turned on or off by
software.
I/O buffer configuration is shown in figure 29, programmable I/O circuits are listed in table 17, and I/O pin
circuit types are shown in table 18.
Table 17 Programmable I/O Circuits
MIS3 (bit 3 of MIS) 0 1
DCD, DCR 0 1 0 1
PDR 01010101
CMOS buffer PMOS — — — On — — — On
NMOS — — On — — — On —
Pull-up MOS — — — — — On — On
Note: — indicates off status.
46
Page 49

HD404829R Series
HLT
MIS3
DCD, DCR
PDR
Pull-up
MOS
V
CC
V
CC
Input control signal
Pull-up control signal
Buffer control signal
Output data
Input data
Figure 29 I/O Buffer Configuration
Table 18 Circuit Configurations of I/O Pins
I/O Pin Type Circuit Pins
Input/output pins
V
CC
V
CC
Input control signal
V
CC
V
CC
Pull-up control signal
Buffer control
signal
Output data
Input data
Pull-up control signal
Buffer control
signal
Output data
Input data
HLT
MIS3
DCD, DCR
PDR
HLT
MIS3
DCR
MIS2
PDR
D0 – D
R00–R0
R10–R1
R20–R2
R30–R3
R40–R4
R50–R5
R60–R6
R70–R7
R2
9
3
3
2
3
3
3
3
3
3
Input pins
Input control signal
Input control signal
Input data
D10, D
11
47
Page 50

HD404829R Series
Table 18 Circuit Configurations of I/O Pins (cont)
I/O Pin Type Circuit Pins
Peripheral
function
pins
Input/output
pins
V
CC
V
CC
Pull-up control signal
HLT
MIS3
SCK
Output pins
Input pins
Output data
Input data
V
CC
V
CC
V
CC
V
CC
V
CC
Pull-up control signal
Pull-up control signal
Output data
Input data
Input data
SCK
PMOS control
signal
Output data
SCK
HLT
MIS3
MIS2
SO
HLT
MIS3
TOB, TOC, TOD
HLT
MIS3
PDR
SI, INT1, etc
INT0, STOPC
SO
TOB, TOC, TOD
SI, INT1, INT2,
INT
, INT4,
3
EVNB, EVND
INT
, STOPC
0
Notes: 1. The MCU is reset in stop mode, and peripheral function selection is cancelled. The HLT signal
becomes low, and input/output pins enter high-impedance state.
2. The HLT signal is 1 in watch and subactive modes.
48
Page 51

HD404829R Series
D Port (D0–D11): Consist of 10 input/output pins and 2 input pins addressed by one bit. D0–D9 are high-
current I/O pins, and D10 and D11 are input-only pins.
Pins D0–D9 are set by the SED and SEDD instructions, and reset by the RED and REDD instructions.
Output data is stored in the port data register (PDR) for each pin. All pins D0–D11 are tested by the TD and
TDD instructions.
The on/off statuses of the output buffers are controlled by D-port data control registers (DCD0–DCD2:
$02C–$02E) that are mapped to memory addresses (figure 30).
Pins D10 and D11 are multiplexed with peripheral function pins STOPC and I NT 0, respectively. The
peripheral function modes of these pins are selected by bits 2 and 3 (PMRC2, PMRC3) of port mode
register C (PMRC: $025) (figure 31).
R Ports (R00–R73): 32 input/output pins addressed in 4-bit units. Data is input to these ports by the LAR
and LBR instructions, and output from them by the LRA and LRB instructions. Output data is stored in the
port data register (PDR) for each pin. The on/off statuses of the output buffers of the R ports are controlled
by R-port data control registers (DCR0–DCR7: $030–$037) that are mapped to memory addresses (figure
30).
Pins R00–R03 are multiplexed with peripheral pins INT1–INT4, respectively. The peripheral function
modes of these pins are selected by bits 0–3 (PMRB0–PMRB3) of port mode register B (PMRB: $024)
(figure 32).
Pins R10–R12 are multiplexed with peripheral pins TOB, TOC, and TOD, respectively. The peripheral
function modes of these pins are selected by bits 0 and 1 (TMB20, TMB21) of timer mode register B2
(TMB2: $013), bits 0–2 (TMC20–TMC22) of timer mode register C2 (TMC2: $014), and bits 0–3
(TMD20–TMD23) of timer mode register D2 (TMD2: $015) (figures 33, 34, and 35).
Pins R13 and R20 are multiplexed with peripheral pins EVNB and EVND, respectively. The peripheral
function modes of these pins are selected by bits 0 and 1 (PMRC0, PMRC1) of port mode register C
(PMRC: $025) (figure 31).
Pins R21–R23 are multiplexed with peripheral pins SCK, SI, and SO, respectively. The peripheral function
modes of these pins are selected by bit 3 (SMRA3) of serial mode register A (SMRA: $005), and bits 0 and
1 (PMRA0, PMRA1) of port mode register A (PMRA: $004), as shown in figures 36 and 37.
Ports R3 and R4 are multiplexed with segment pins SEG1–SEG8, respectively. The function modes of
these pins can be selected by individual pins, by setting LCD output registers 1 and 2 (LOR1, LOR2: $01D,
$01F) (figures 38 and 39).
Ports R5–R7 are multiplexed with segment pins SEG9–SEG20, respectively. The function modes of these
pins can be selected in 4-pin units by setting LCD output register 3 (LOR3: $01F) (figure 40).
49
Page 52

HD404829R Series
Data control register (DCD0 to 2: $02C to $02E)
(DCR0 to 7: $030 to $037)
DCD0, DCD1
Bit
Initial value
Read/Write
Bit name
3
0
W
DCD03,
2
0
W
DCD02,
1
0
W
DCD01,
0
0
W
DCD00,
DCD13 DCD12 DCD10DCD11
DCD2
Bit
Initial value
Read/Write
Bit name
3
—
—
Not used
2
—
—
Not used
1
0
W
DCD21
0
0
W
DCD20
DCR0 to DCR7
Bit
Initial value
Read/Write
Bit name
3
0
W
DCR03–
2
0
W
DCR02–
1
0
W
DCR01–
0
0
W
DCR00–
DCR73 DCR72 DCR70DCR71
All Bits CMOS Buffer On/Off Selection
0 Off (high-impedance)
1On
Correspondence between ports and DCD/DCR bits
Register Name Bit 3 Bit 2 Bit 1 Bit 0
DCD0 D
DCD1 D
3
7
D
2
D
6
DCD2 — — D
DCR0 R0
DCR1 R1
DCR2 R2
DCR3 R3
DCR4 R4
DCR5 R5
DCR6 R6
DCR7 R7
3
3
3
3
3
3
3
3
R0
R1
R2
R3
R4
R5
R6
R7
2
2
2
2
2
2
2
2
D
D
R0
R1
R2
R3
R4
R5
R6
R7
1
5
9
1
1
1
1
1
1
1
1
D
D
D
R0
R1
R2
R3
R4
R5
R6
R7
0
4
8
0
0
0
0
0
0
0
0
Figure 30 Data Control Registers (DCD, DCR)
50
Page 53
Port mode register C (PMRC: $025)
HD404829R Series
Bit
Initial value
Read/Write
Bit name
PMRC3
0
1
PMRC2
0
1
*
Note: PMRC2 is reset to 0 only by RESET input. When STOPC is input in stop
3
0
W
PMRC3
PMRC2
D11/INT0 mode selection
D
11
INT
0
D10/STOPC mode selection
D
10
STOPC
mode, PMRC2 is not reset but retains its value.
Figure 31 Port Mode Register C (PMRC)
Port mode register B (PMRB: $024)
Bit
Initial value
Read/Write
Bit name
3
0
W
PMRB3
2
0
W
PMRB2
PMRB1
W
W
2
0
1
0
W
*
PMRC1
1
0
0
0
0
0
W
PMRC0
PMRC0
0
1
PMRC1
0
1
R13/EVNB mode selection
R1
3
EVNB
R20/EVND mode selection
R2
0
EVND
W
PMRB0
PMRB3
0
1
PMRB2
0
1
R0
/INT4 mode selection
3
R0
3
INT
4
R0
/INT3 mode selection
2
R0
2
INT
3
Figure 32 Port Mode Register B (PMRB)
PMRB0
0
1
PMRB1
0
1
R00/INT1 mode selection
R0
0
INT
1
R0
/INT2 mode selection
1
R0
1
INT
2
51
Page 54
HD404829R Series
Timer mode register B2 (TMB2: $013)
Bit
Initial value
Read/Write
Bit name
TMB21
0
1
Not used
TMB20
0
1
0
1
3
—
—
2
—
—
Not used
R1
/TOB mode selection
0
R1
0
TOB
TOB
TOB
R/W
TMB21
R1
port
0
Toggle output
0 output
1 output
Figure 33 Timer Mode Register B2 (TMB2)
Timer mode register C2 (TMC2: $014)
Bit
Initial value
Read/Write
Bit name
3
—
—
Not used
2
0
R/W
TMC22
1
0
R/W
TMC21
1
0
0
0
R/W
TMB20
0
0
R/W
TMC20
TMC22 TMC20
TMC21
0
0
0
1
1
0
1
1
0
0
R1
/TOC mode selection
1
1
R1
Toggle output
0 output
1 output
Not used
R1
TOC
TOC
TOC
—
1
1
0
1
TOC
PWM output
Figure 34 Timer Mode Register C2 (TMC2)
port
1
52
Page 55

Timer mode register D2 (TMD2: $015)
HD404829R Series
Bit
Initial value
Read/Write
Bit name
TMD23
TMD22 TMD20
0
1
✕: Don’t care
3
0
R/W
TMD23
0
1
TMD22
TMD21
0
1
0
2
0
R/W
R/W
TMD21
0
1
0
1
0
1
0
0
0
R/W
TMD20
R1
/TOD mode selection
2
R1
2
R12 port
TOD
TOD
TOD
—
Toggle output
0 output
1 output
Not used
1
1
✕✕✕
0
1
TOD
R1
PWM output
Input capture (R1
2
Figure 35 Timer Mode Register D2 (TMD2)
port)
2
Serial mode register A (SMRA: $005)
Bit
Initial value
Read/Write
Bit name
SMRA3
0
1
3
0
W
SMRA3
R21/SCK
mode selection
R2
1
SCK
SMRA2
2
0
W
SMRA1
SMRA2 SMRA0SMRA1 Clock source
0
1
Figure 36 Serial Mode Register A (SMRA)
1
0
W
0
0
W
SMRA0
0
1
0
1
Prescaler
SCK
Output
0
Output
1
Output
0
Output
1
Output
0
Output
1
Output
0
Input
1
Prescaler
Prescaler
Prescaler
Prescaler
Prescaler
Prescaler
System clock
External clock
division
ratio
÷2048
÷512
÷128
÷32
÷8
÷2
—
—
53
Page 56

HD404829R Series
Port mode register A (PMRA: $004)
Bit
Initial value
Read/Write
Bit name
PMRA1
0
1
3
—
—
Not used
2
—
—
Not used
R22/SI mode selection
R2
2
SI
Figure 37 Port Mode Register A (PMRA)
LCD output register 1 (LOR1: $01D)
Bit
Initial value
Read/Write
Bit name
LOR13
0
1
3
0
W
LOR13
R33/SEG4 mode selection
R3
3
SEG4
PMRA1
2
0
W
LOR12
1
0
W
PMRA0
1
0
W
LOR11
0
0
W
PMRA0
0
1
LOR10
LOR11
0
1
R23/SO mode selection
R2
3
SO
0
0
W
R31/SEG2 mode selection
R3
1
SEG2
LOR12
0
1
R32/SEG3 mode selection
R3
2
SEG3
LOR10
0
1
Figure 38 LCD Output Register 1 (LOR1)
R30/SEG1 mode selection
R3
0
SEG1
54
Page 57
LCD output register 2 (LOR2: $01E)
HD404829R Series
Bit
Initial value
Read/Write
Bit name
LOR23
0
1
LOR22
0
1
3
0
W
LOR23
R43/SEG8 mode selection
R4
3
SEG8
R42/SEG7 mode selection
R4
2
SEG7
Figure 39 LCD Output Register 2 (LAOR2)
LCD output register 3 (LOR3: $01F)
Bit
Initial value
Read/Write
Bit name
3
—
—
Not used
2
0
W
LOR32
W
LOR22
1
0
W
LOR31
2
0
W
LOR21
0
0
W
LOR30
1
0
LOR20
LOR21
0
1
LOR20
0
1
0
0
W
R41/SEG6 mode selection
R4
1
SEG6
R40/SEG5 mode selection
R4
0
SEG5
LOR32
0
1
R70/SEG17–R73/SEG20 mode selection
R7
–R7
0
3
SEG17–SEG20
Figure 40 LCD Output Register 3 (LOR3)
LOR31
0
1
LOR30
0
1
R60/SEG13–R63/SEG16 mode selection
R6
–R6
0
3
SEG13–SEG16
R50/SEG9–R53/SEG12 mode selection
R5
–R5
0
3
SEG9–SEG12
55
Page 58
HD404829R Series
Pull-Up MOS Transistor Control: A program-controlled pull-up MOS transistor is provided for each
input/output pin other than input-only pins D10 and D11. The on/off status of all these transistors is
controlled by bit 3 (MIS3) of the miscellaneous register (MIS: $00C), and the on/off status of an individual
transistor can also be controlled by the port data register (PDR) of the corresponding pin—enabling on/off
control of that pin alone (table 17 and figure 41).
The on/off status of each transistor and the peripheral function mode of each pin can be set independently.
How to Deal with Unused I/O Pins: I/O pins that are not needed by the user system (floating) must be
connected to VCC to prevent LSI malfunctions due to noise. These pins must either be pulled up to VCC by
their pull-up MOS transistors or by resistors of about 100 kΩ.
Miscellaneous register (MIS: $00C)
Bit
Initial value
Read/Write
Bit name
MIS3
0
1
3
0
W
MIS3
Pull-up MOS
on/off selection
Off
On
MIS2
W
2
0
1
0
W
MIS1
MIS2
0
1
0
0
W
MIS0
CMOS buffer
on/off selection
for pin R23/SO
On
Off
Figure 41 Miscellaneous Register (MIS)
MIS1 MIS0
t
selection.
RC
Refer to figure 18 in the
operation modes section.
56
Page 59
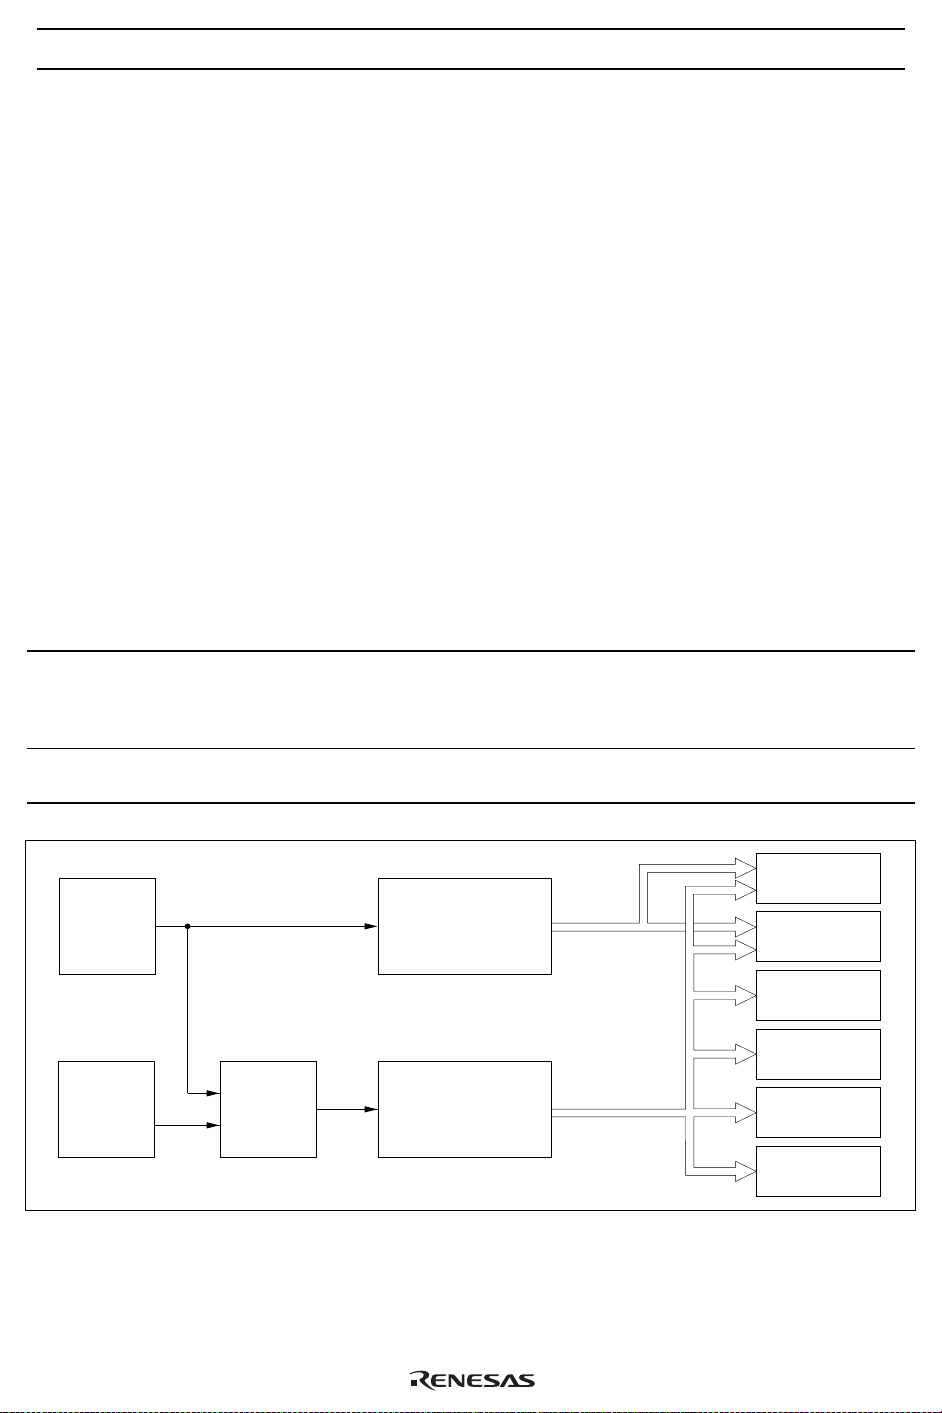
HD404829R Series
Prescalers
The MCU has the following two prescalers, S and W.
The prescalers operating conditions are listed in table 19, and the prescalers output supply is shown in
figure 42. The timers A–D input clocks except external events, the serial transmit clock except the external
clock, and the LCD circuit operating clock are selected from the prescaler outputs, depending on
corresponding mode registers.
Prescaler Operation
Prescaler S: 11-bit counter that inputs the system clock signal. After being reset to $000 by MCU reset,
prescaler S divides the system clock. Prescaler S keeps counting, except in watch and subactive modes and
at MCU reset.
Prescaler W: Five-bit counter that inputs the X1 input clock signal (32-kHz crystal oscillation) divided by
eight. After being reset to $00 by MCU reset, prescaler W divides the input clock. Prescaler W can be
reset by software.
Table 19 Prescaler Operating Conditions
Prescaler Input Clock Reset Conditions Stop Conditions
Prescaler S System clock (in active and
standby mode),
Subsystem clock (in subactive
mode)
Prescaler W 32-kHz crystal oscillation MCU reset,
MCU reset MCU reset,
stop mode,
watch mode
MCU reset,
software
stop mode
Subsystem
clock
System
clock
Clock
selector
Prescaler W
Prescaler S
Figure 42 Prescaler Output Supply
LCD
Timer A
Timer B
Timer C
Timer D
Serial
57
Page 60

HD404829R Series
Timers
The MCU has four timer/counters (A to D).
• Timer A: Free-running timer
• Timer B: Multifunction timer
• Timer C: Multifunction timer
• Timer D: Multifunction timer
Timer A is an 8-bit free-running timer. Timers B–D are 8-bit multifunction timers, whose functions are
listed in table 20. The operating modes are selected by software.
Table 20 Timer Functions
Functions Timer A Timer B Timer C Timer D
Clock Prescaler S Available Available Available Available source Prescaler W Available — — —
External event — Available — Available
Timer Free-running Available Available Available Available
functions Time-base Available — — —
Event counter — Available — Available
Reload — Available Available Available
Watchdog — — Available —
Input capture — — — Available
Timer Toggle — Available Available Available
outputs 0 output — Available Available Available
1 output — Available Available Available
PWM — — Available Available
Note: — implies not available.
Timer A
Timer A Functions: Timer A has the following functions.
• Free-running timer
• Clock time-base
The block diagram of timer A is shown in figure 43.
58
Page 61

HD404829R Series
32.768-kHz
oscillator
System
clock
Data bus
Clock line
Signal line
1/4 1/2
2 f
1/2 tw
ø
PER
f
Prescaler W
W
tw
cyc
W
cyc
24832128
ччччччч
Prescaler S (PSS)
(PSW)
2816
÷÷÷
Selector
Selector
512
32
÷
1024
2048
÷
Clock
Selector
3
Figure 43 Block Diagram of Timer A
Timer A interrupt
request flag
(IFTA)
Timer
counter A
(TCA)
Timer mode
register A
(TMA)
Overflow
Internal data bus
Timer A Operations:
• Free-running timer operation: The input clock for timer A is selected by timer mode register A (TMA:
$008).
• Timer A is reset to $00 by MCU reset and
incremented at each input clock. If an input clock is applied to timer A after it has reached
• $FF, an overflow is generated, and timer A is reset to $00. The overflow sets the timer A interrupt
request flag (IFTA: $001, bit 2). Timer A continues to be incremented after reset to $00, and therefore
it generates regular interrupts every 256 clocks.
• Clock time-base operation: Timer A is used as a clock time-base by setting bit 3 (TMA3) of timer
mode register A (TMA: $008) to 1. The prescaler W output is applied to timer A, and timer A
generates interrupts at the correct timing based on the 32.768-kHz crystal oscillation. In this case,
prescaler W and timer A can be reset to $00 by software.
Registers for Timer A Operation: Timer A operating modes are set by the following registers.
• Timer mode register A (TMA: $008): Four-bit write-only register that selects timer A’s operating mode
and input clock source as shown in figure 44.
59
Page 62
HD404829R Series
Timer mode register A (TMA: $008)
Bit
Initial value
Read/Write
Bit name
3
0
W
TMA3
TMA3 TMA1TMA2 TMA0
0
00
0
1
0
1
1
0
0
1
1
0
1
1
0
1
00
1
0
1
1
1
0
0
1
1
✕
2
0
W
TMA2
Source
prescaler
PSS
PSS
PSS
PSS
PSS
PSS
PSS
PSS
PSW
PSW
PSW
PSW
—
—
—
1
0
W
TMA1
0
0
W
TMA0
Input clock
frequency
2048t
cyc
1024t
cyc
512t
cyc
128t
cyc
32t
cyc
8t
cyc
4t
cyc
2t
cyc
32t
Wcyc
16t
Wcyc
8t
Wcyc
2t
Wcyc
1/2t
Wcyc
Not used
Reset PSW and TCA
Operating mode
Timer A mode
Time-base mode
✕ : Don’t care
Note: 1.
t
Wcyc
2.
Timer counter overflow output period (seconds) = input clock period (seconds) × 256.
3.
If PSW of TCA reset is selected while the LCD is operating, LCD operation halts (power switch
goes off and all SEG and COM pins are grounded).
When an LCD is connected for display, the PSW and TCA reset periods must be set in the
program to the minimum.
The division ratio must not be modified during time-base mode operation, otherwise an overflow
4.
cycle error will occur.
60
= 244.14 µs (when a 32.768-kHz crystal oscillator is used)
Figure 44 Timer Mode Register A (TMA)
Page 63

Timer B
Timer B Functions: Timer B has the following functions.
• Free-running/reload timer
• External event counter
• Timer output operation (toggle, 0, and 1 outputs)
The block diagram of timer B is shown in figure 45.
TOB
EVNB
System
clock
Timer output
control logic
φ
PER
÷2
÷4
÷8
÷32
(PSS)
÷128
Prescaler S
÷512
÷2048
Selector
3
Free-runnning/Reload control
Timer mode
register B1
(TMB1)
Timer read
register BU
Timer read
register BL
(TRBL)
4
Timer counter B
(TCBL) (TCBU)
4 4
Timer counter B
(TWBL) (TWBU)
(TRBU)
HD404829R Series
Timer B ineterrupt
request flag
(IFTB)
Overflow
Internal data bus
2
Edge detection
control
Data bus
Clock line
Signal line
Timer mode
register B2
(TMB2)
Figure 45 Block Diagram of Timer B
61
Page 64
HD404829R Series
Timer B Operations:
• Free-running/reload timer operation: The free-running/reload operation, input clock source, and
prescaler division ratio are selected by timer mode register B1 (TMB1: $009).
Timer B is initialized to the value set in timer write register B (TWBL: $00A, TWBU: $00B) by
software and incremented by one at each clock input. If an input clock is applied to timer B after it has
reached $FF, an overflow is generated. In this case, if the reload timer function is enabled, timer B is
initialized to its initial value set in timer write register B; if the free-running timer function is enabled,
the timer is initialized to $00 and then incremented again.
The overflow sets the timer B interrupt request flag (IFTB: $002, bit 0). IFTB is reset by software or
MCU reset. Refer to figure 3 and table 1 for details.
• External event counter operation: Timer B is used as an external event counter by selecting external
event input as input clock source. In this case, pin R13/EVNB must be set to EVNB by port mode
register C (PMRC: $025).
Timer B is incremented by one at each falling edge of signals input to pin EVNB. The other operation
is basically the same as the free-running/reload timer operation.
• Timer output operation: The following three output modes can be selected for timer B by setting timer
mode register B2 (TMB2: $013).
Toggle
0 output
1 output
By selecting the timer output mode, pin R10/TOB is set to TOB. The output from TOB is reset low by
MCU reset.
Toggle output: When toggle output mode is selected, the output level is inverted if a clock is input
after timer B has reached $FF. By using this function and reload timer function, clock signals can
be output at a required frequency for the buzzer. The output waveform is shown in figure 46.
0 output: When 0 output mode is selected, the output level is pulled low if a clock is input after
timer B has reached $FF. Note that this function must be used only when the output level is high.
1 output: When 1 output mode is selected, the output level is set high if a clock is input after timer
B has reached $FF. Note that this function must be used only when the output level is low.
62
Page 65
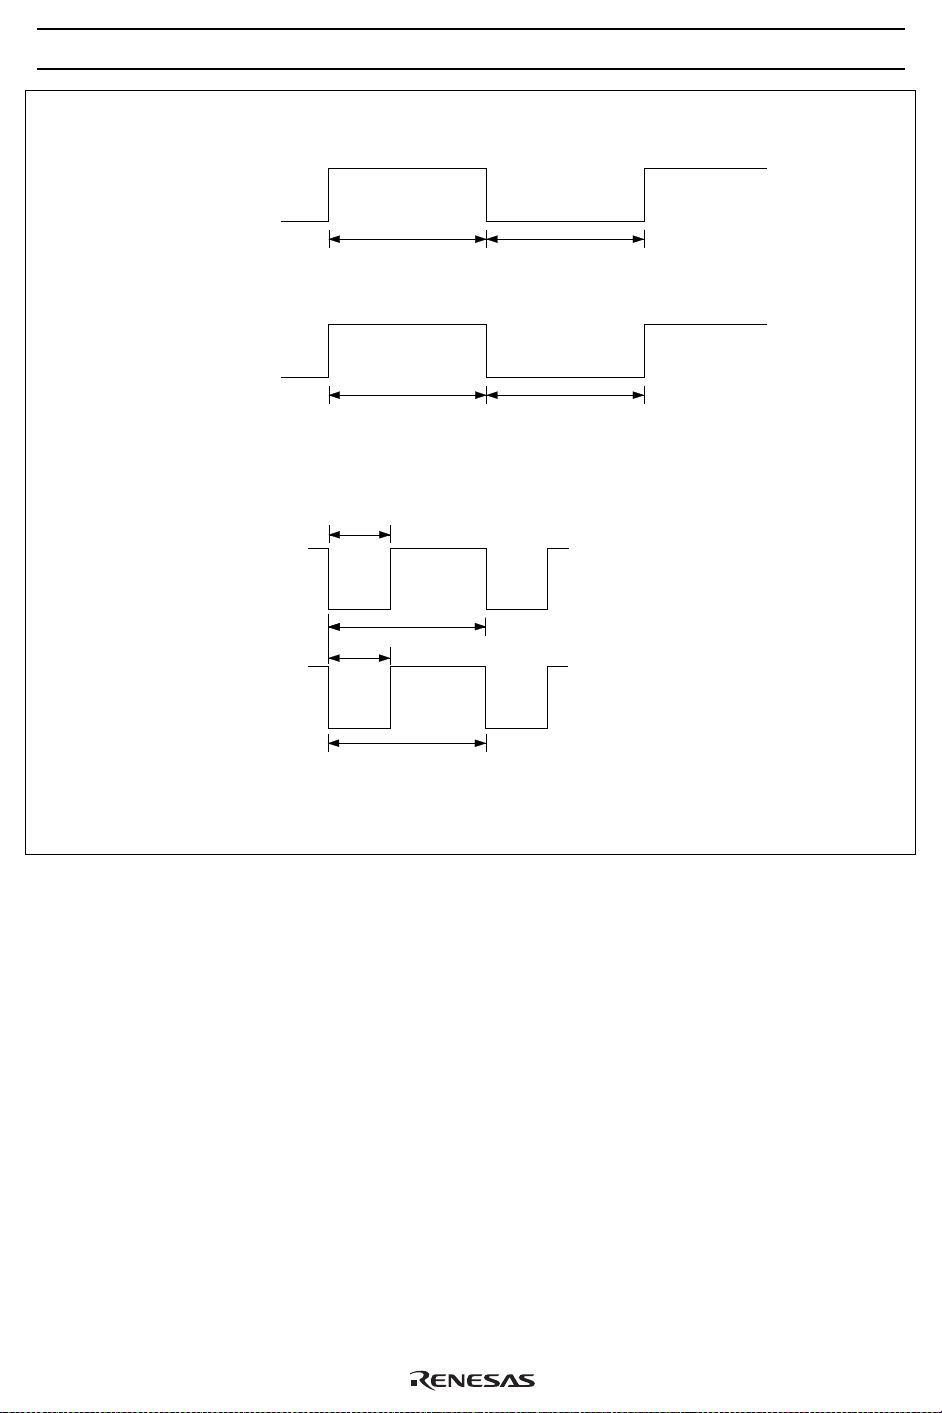
Toggle output waveform (timers B, C, and D)
Free-running timer
256 clock cycles 256 clock cycles
Reload timer
(256 – N) clock cycles (256 – N) clock cycles
PWM output waveform (timers C and D)
×
T (N + 1)
TMC13 = 0
TMD13 = 0
×
T 256
T
HD404829R Series
TMC13 = 1
TMD13 = 1
Note:
×
T (256 – N)
The waveform is always fixed low when N = $FF.
Input clock period to counter (figures 52 and 60)
T:
The value of the timer write register
N:
Figure 46 Timer Output Waveform
63
Page 66

HD404829R Series
Registers for Timer B Operation: By using the following registers, timer B operation modes are selected
and the timer B count is read and written.
Timer mode register B1 (TMB1: $009)
Timer mode register B2 (TMB2: $013)
Timer write register B (TWBL: $00A, TWBU: $00B)
Timer read register B (TRBL: $00A, TRBU: $00B)
Port mode register C (PMRC: $025)
• Timer mode register B1 (TMB1: $009):
Four-bit write-only register that selects the free-running/reload timer function, input clock source, and
the prescaler division ratio as shown in figure 47. It is reset to $0 by MCU reset.
Writing to this register is valid from the second instruction execution cycle after the execution of the
previous timer mode register B1 write instruction. Setting timer B’s initialization by writing to timer
write register B (TWBL: $00A, TWBU: $00B) must be done after a mode change becomes valid.
Timer mode register B1 (TMB1: $009)
Bit
Initial value
Read/Write
Bit name
TMB13
0
1
3
0
W
TMB13
Free-running/reload
timer selection
Free-running timer
Reload timer
2
0
W
TMB12
Figure 47 Timer Mode Register B1 (TMB1)
Timer mode register B2 (TMB2: $013)
Bit
Initial value
Read/Write
Bit name
3
—
—
Not used
2
—
—
Not used
R/W
TMB21
1
0
W
TMB11
1
0
TMB10
TMB12 TMB10TMB11
0
1
0
0
R/W
TMB20
0
0
W
Input clock period and input
clock source
2048t
TMB21
0
1
0
1
0
1
0
1
0
1
cyc
512t
cyc
128t
cyc
32t
cyc
8t
cyc
4t
cyc
2t
cyc
R1
/EVNB (external event input)
3
TMB20
R1
/TOB mode selection
0
0
R1
0
1
TOB
0
TOB
1
TOB
R1
port
0
Toggle output
0 output
1 output
0
1
0
1
64
Figure 48 Timer Mode Register B2 (TMB2)
Page 67
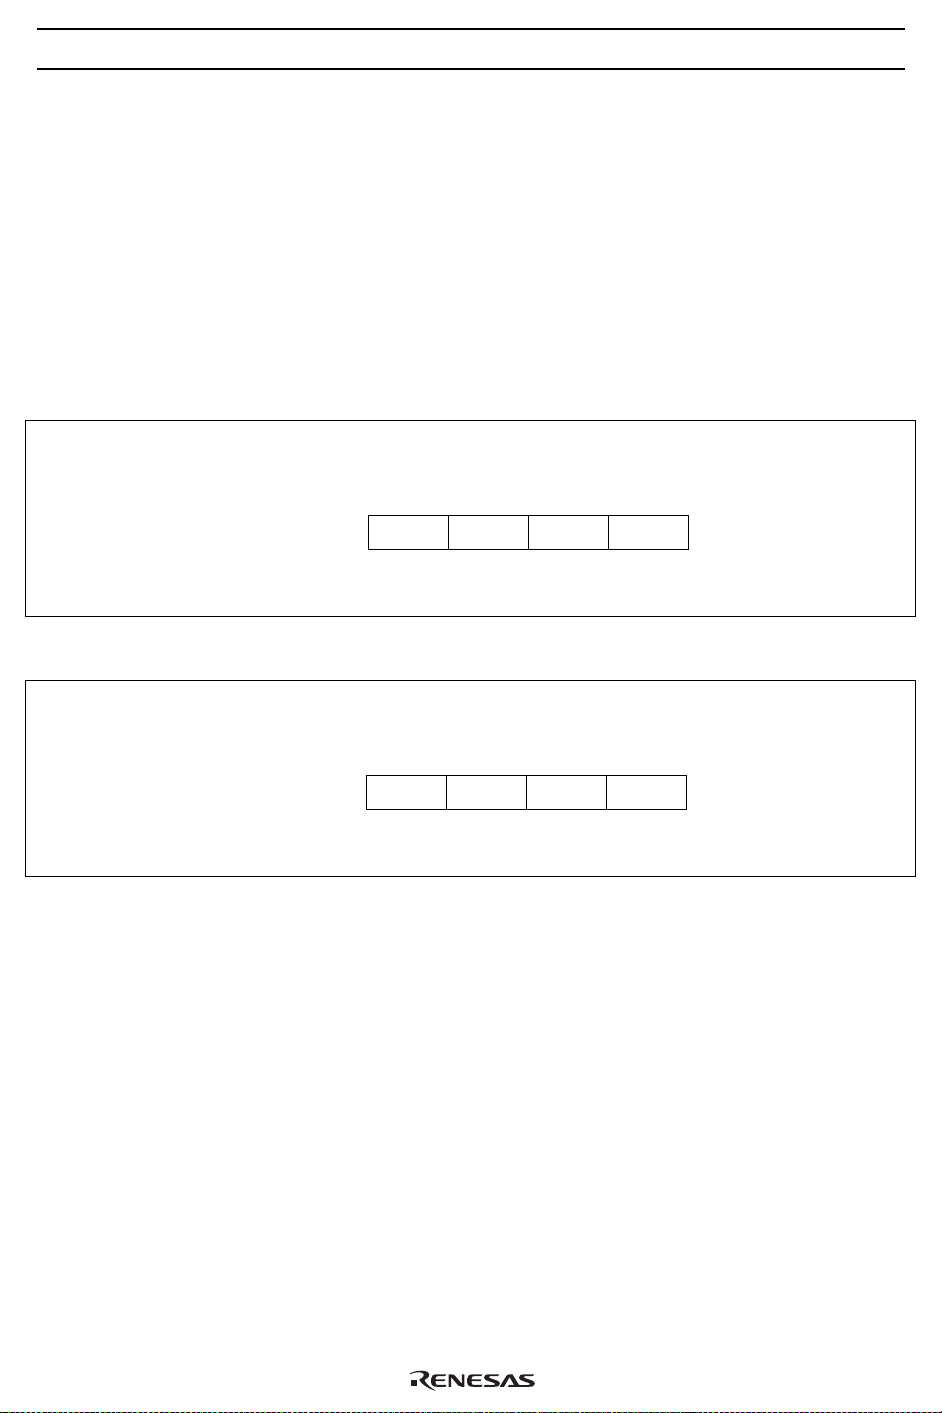
HD404829R Series
• Timer mode register B2 (TMB2: $013): Two-bit read/write register that selects the timer B output
mode as shown in figure 48. It is reset to $0 by MCU reset.
• Timer write register B (TWBL: $00A, TWBU: $00B): Write-only register consisting of the lower digit
(TWBL) and the upper digit (TWBU) as shown in figures 49 and 50. The lower digit is reset to $0 by
MCU reset, but the upper digit value is invalid.
Timer B is initialized by writing to timer write register B. In this case, the lower digit (TWBL) must be
written to first, but writing only to the lower digit does not change the timer B value. Timer B is
initialized to the value in timer write register B at the same time the upper digit (TWBU) is written to.
When timer write register B is written to again and if the lower digit value needs no change, writing
only to the upper digit initializes timer B.
Timer write register B (lower digit) (TWBL: $00A)
Bit
Initial value
Read/Write
Bit name
3
0
W
TWBL3
2
0
W
TWBL2
1
0
W
TWBL1
0
0
W
TWBL0
Figure 49 Timer Write Register B Lower Digit (TWBL)
Timer write register B (upper digit) (TWBU: $00B)
Bit
Initial value
Read/Write
Bit name
3
Undefined
W
TWBU3
2
Undefined
W
TWBU2
1
Undefined
W
TWBU1
0
Undefined
W
TWBU0
Figure 50 Timer Write Register B Upper Digit (TWBU)
• Timer read register B (TRBL: $00A, TRBU: $00B): Read-only register consisting of the lower digit
(TRBL) and the upper digit (TRBU) that holds the count of the timer B upper digit (figures 51 and 52).
The upper digit (TRBU) must be read first. At this time, the count of the timer B upper digit is
obtained, and the count of the timer B lower digit is latched to the lower digit (TRBL). After this, by
reading TRBL, the count of timer B when TRBU is read can be obtained.
65
Page 68
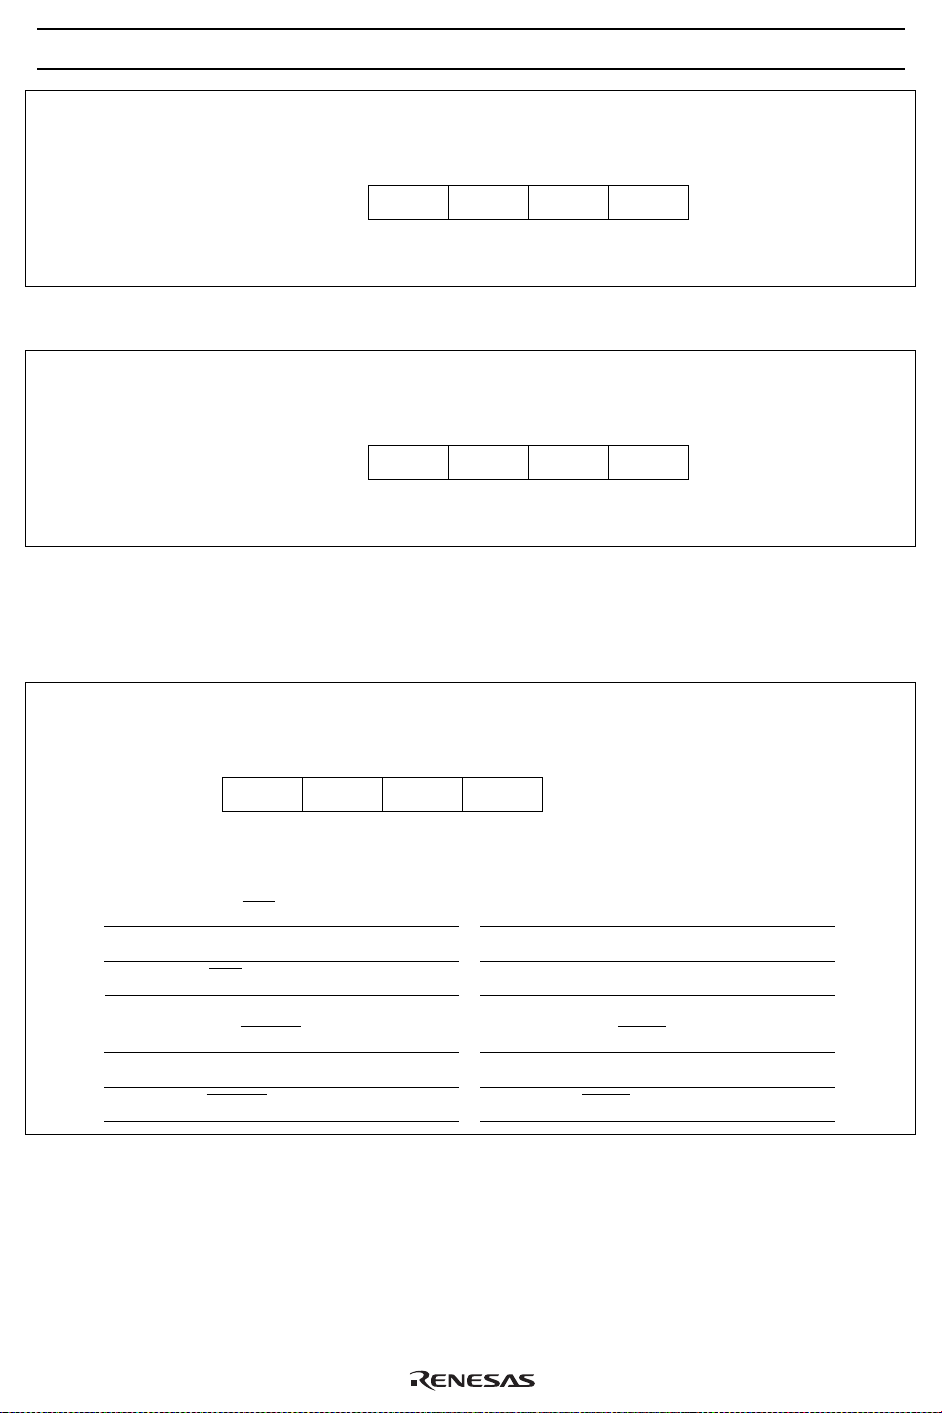
HD404829R Series
Timer read register B (lower digit) (TRBL: $00A)
Bit
Initial value
Read/Write
Bit name
3
Undefined
R
TRBL3
2
Undefined
R
TRBL2
1
Undefined
R
TRBL1
0
Undefined
R
TRBL0
Figure 51 Timer Read Register B Lower Digit (TRBL)
Timer read register B (upper digit) (TRBU: $00B)
Bit
Initial value
Read/Write
Bit name
3
Undefined
R
TRBU3
2
Undefined
R
TRBU2
1
Undefined
R
TRBU1
0
Undefined
R
TRBU0
Figure 52 Timer Read Register B Upper Digit (TRBU)
• Port mode register C (PMRC: $025): Write-only register that selects R13/EVNB pin function as shown
in figure 53. It is reset to $0 by MCU reset.
Port mode register C (PMRC: $025)
Bit
Initial value
Read/Write
Bit name
PMRC3
0
1
PMRC2
0
1
3
0
W
PMRC3
2
0
W
PMRC2
1
0
W
PMRC1
D11/INT0 mode selection
D
11
INT
0
D10/STOPC mode selection
D
10
STOPC
Figure 53 Port Mode Register C (PMRC)
0
0
W
PMRC0
PMRC1
0
1
PMRC0
0
1
R20/EVND mode selection
R2
0
EVND
R13/EVNB mode selection
R1
3
EVNB
66
Page 69

Timer C
Timer C Functions: Timer C has the following functions.
• Free-running/reload timer
• Watchdog timer
• Timer output operation (toggle, 0, 1, and PWM outputs)
The block diagram of timer C is shown in figure 54.
HD404829R Series
67
Page 70
HD404829R Series
System reset signal
TOC
System
clock
Timer output
control logic
ø
PER
Prescalers
(PSS)
Watchdog on
flag
(WDON)
÷2
÷ 4
÷ 8
÷ 32
÷ 128
÷ 512
÷ 1024
÷ 2048
Selector
Watchdog timer
control logic
3
Timer read
register CL
(TRCL)
4
Timer counter C
(TCCL) (TCCU)
4 4
Timer write register C
(TWCL) (TWCU)
Timer C
interrupt request
flag
(IFTC)
Timer read
register CU
(TRCU)
Internal data bus
3
Data bus
Clock line
Signal line
Free-running/reload control
Timer output
control
Timer mode
register C1
(TMC1)
Timer mode
register C2
(TMC2)
Figure 54 Block Diagram of Timer C
68
Page 71
HD404829R Series
Timer C Operations:
• Free-running/reload timer operation: The free-running/reload operation, input clock source, and
prescaler division ratio are selected by timer mode register C1 (TMC1: $00D).
Timer C is initialized to the value set in timer write register C (TWCL: $00E, TWCU: $00F) by
software and incremented by one at each clock input. If an input clock is applied to timer C after it has
reached $FF, an overflow is generated. In this case, if the reload timer function is enabled, timer C is
initialized to its initial value set in timer write register C; if the free-running timer function is enabled,
the timer is initialized to $00 and then incremented again.
The overflow sets the timer C interrupt request flag (IFTC: $002, bit 2). IFTC is reset by software or
MCU reset. Refer to figure 3 and table 1 for details.
• Watchdog timer operation: Timer C is used as a watchdog timer for detecting out-of-control program
routines by setting the watchdog on flag (WDON: $020, bit 1) to 1. If a program routine runs out of
control and an overflow is generated, the MCU is reset. Program run can be controlled by initializing
timer C by software before it reaches $FF.
• Timer output operation: The following four output modes can be selected for timer C by setting timer
mode register C2 (TMC2: $014).
Toggle
0 output
1 output
PWM output
By selecting the timer output mode, pin R11/TOC is set to TOC. The output from TOC is reset low by
MCU reset.
Toggle output: The operation is basically the same as that of timer-B’s toggle output.
0 output: The operation is basically the same as that of timer-B’s 0 output.
1 output: The operation is basically the same as that of timer-B’s 1 output.
PWM output: When PWM output mode is selected, timer C provides the variable-duty pulse output
function. The output waveform differs depending on the contents of timer mode register C1
(TMC1: $00D) and timer write register C (TWCL: $00E, TWCU: $00F). The output waveform is
shown in figure 46.
69
Page 72
HD404829R Series
Registers for Timer C Operation: By using the following registers, timer C operation modes are selected
and the timer C count is read and written.
Timer mode register C1 (TMC1: $00D)
Timer mode register C2 (TMC2: $014)
Timer write register C (TWCL: $00E, TWCU: $00F)
Timer read register C (TRCL: $00E, TRCU: $00F)
• Timer mode register C1 (TMC1: $00D): Four-bit write-only register that selects the free-running/reload
timer function, input clock source, and the prescaler division ratio as shown in
figure 55. It is reset to $0 by MCU reset.
Writing to this register is valid from the second instruction execution cycle after the execution of the
previous timer mode register C1 write instruction. Setting timer C’s initialization by writing to timer
write register C (TWCL: $00E, TWCU: $00F) must be done after a mode change becomes valid.
Timer mode register C1 (TMC1: $00D)
Bit
Initial value
Read/Write
Bit name
TMC13
0
1
3
0
W
TMC13
Free-running/reload timer selection
Free-running timer
Reload timer
2
0
W
TMC12
1
0
W
TMC11
Figure 55 Timer Mode Register C1 (TMC1)
0
0
W
TMC10
TMC12 TMC10TMC11
0
1
Input clock period
0
1
0
1
0
1
0
1
0
1
0
1
2048t
1024t
512t
128t
32t
cyc
8t
cyc
4t
cyc
2t
cyc
cyc
cyc
cyc
cyc
70
Page 73

HD404829R Series
• Timer mode register C2 (TMC2: $014): Three-bit read/write register that selects the timer C output
mode as shown in figure 56. It is reset to $0 by MCU reset.
• Timer write register C (TWCL: $00E, TWCU: $00F): Write-only register consisting of the lower digit
(TWCL) and the upper digit (TWCU). The operation of timer write register C is basically the same as
that of timer write register B (TWBL: $00A, TWBU: $00B).
• Timer read register C (TRCL: $00E, TRCU: $00F): Read-only register consisting of the lower digit
(TRCL) and the upper digit (TRCU) that holds the count of the timer C upper digit. The operation of
timer read register C is basically the same as that of timer read register B (TRBL: $00A, TRBU: $00B).
Timer mode register C2 (TMC2: $014)
Bit
Initial value
Read/Write
Bit name
3
—
—
Not used
2
0
R/W
TMC22
TMC220TMC21 R11/TOC mode selection
10
1
0
R/W
TMC21
0
1
1
0
0
R/W
TMC20
TMC20
0
1
0
1
0
1
0
1
Figure 56 Timer Mode Register C2 (TMC2)
R1
TOC
TOC
TOC
—
TOC
1
R1
port
1
Toggle output
0 output
1 output
Not used
PWM output
71
Page 74

HD404829R Series
Timer write register C (lower digit) (TWCL: $00E)
Bit
Initial value
Read/Write
Bit name
3
0
W
TWCL3
2
0
W
TWCL2
1
0
W
TWCL1
0
0
W
TWCL0
Figure 57 Timer Write Register C Lower Digit (TWCL)
Timer write register C (upper digit) (TWCU: $00F)
Bit
Initial value
Read/Write
Bit name
3
Undefined
W
TWCU3
2
Undefined
W
TWCU2
1
Undefined
W
TWCU1
0
Undefined
W
TWCU0
Figure 58 Timer Write Register C Upper Digit (TWCU)
Timer read register C (lower digit) (TRCL: $00E)
Bit
Initial value
Read/Write
Bit name
3
Undefined
R
TRCL3
2
Undefined
R
TRCL2
1
Undefined
R
TRCL1
0
Undefined
R
TRCL0
72
Figure 59 Timer Read Register C Lower Digit (TRCL)
Timer read register C (upper digit) (TRCU: $00F)
Bit
Initial value
Read/Write
Bit name
3
Undefined
R
TRCU3
2
Undefined
R
TRCU2
1
Undefined
R
TRCU1
0
Undefined
R
TRCU0
Figure 60 Timer Read Register C Upper Digit (TRCU)
Page 75

HD404829R Series
Timer D
Timer D Functions: Timer D has the following functions.
• Free-running/reload timer
• External event counter
• Timer output operation (toggle, 0, 1, and PWM outputs)
• Input capture timer
The block diagram for each operation mode of timer D is shown in figures 61 and 62.
Timer D Operations:
• Free-running/reload timer operation: The free-running/reload operation, input clock source, and
prescaler division ratio are selected by timer mode register D1 (TMD1: $010).
Timer D is initialized to the value set in timer write register D (TWDL: $011, TWDU: $012) by
software and incremented by one at each clock input. If an input clock is applied to timer D after it has
reached $FF, an overflow is generated. In this case, if the reload timer function is enabled, timer D is
initialized to its initial value set in timer write register D; if the free-running timer function is enabled,
the timer is initialized to $00 and then incremented again.
The overflow sets the timer D interrupt request flag (IFTD: $003, bit 0). IFTD is reset by software or
MCU reset. Refer to figure 3 and table 1 for details.
• External event counter operation: Timer D is used as an external event counter by selecting the
external event input as an input clock source. In this case, pin R20/EVND must be set to EVND by port
mode register C (PMRC: $025).
Either falling or rising edge, or both falling and rising edges of input signals can be selected as the
external event detection edge by detection edge select register 2 (ESR2: $027). When both rising and
falling edges detection is selected, the time between the falling edge and rising edge of input signals
must be 2t
Timer D is incremented by one at each detection edge selected by detection edge select register 2
(ESR2: $027). The other operation is basically the same as the free-running/reload timer operation.
• Timer output operation: The following four output modes can be selected for timer D by setting timer
mode register D2 (TMD2: $015).
Toggle
0 output
1 output
PWM output
By selecting the timer output mode, pin R12/TOD is set to TOD. The output from TOD is reset low by
MCU reset.
Toggle output: The operation is basically the same as that of timer-B’s toggle output.
0 output: The operation is basically the same as that of timer-B’s 0 output.
1 output: The operation is basically the same as that of timer-B’s 1 output.
PWM output: The operation is basically the same as that of timer-C’s PWM output.
or longer.
cyc
73
Page 76

HD404829R Series
• Input capture timer operation: The input capture timer counts the clock cycles between trigger edges
input to pin EVND.
Either falling or rising edge, or both falling and rising edges of input signals can be selected as the
trigger input edge by detection edge select register 2 (ESR2: $027).
When a trigger edge is input to EVND, the count of timer D is written to timer read register D (TRDL:
$011, TRDU: $012), and the timer D interrupt request flag (IFTD: $003, bit 0) and the input capture
status flag (ICSF: $021, bit 0) are set. Timer D is reset to $00, and then incremented again. While
ICSF is set, if a trigger input edge is applied to timer D, or if timer D generates an overflow, the input
capture error flag (ICEF: $021, bit 1) is set. ICSF and ICEF are reset to 0 by MCU reset or by writing
0.
By selecting the input capture operation, pin R12/TOD is set to R12 and timer D is reset to $00.
74
Page 77
EVND
System
clock
Edge detection
logic
øPER
HD404829R Series
Timer D interrupt
request flag
(IFTD)
Timer read register
DU (TRDU)
Timer read
register DL
(TRDL)
Data bus
Clock line
Signal line
÷ 2
÷ 4
÷ 8
÷ 32
÷ 128
÷ 512
Prescaler S (PSS)
÷ 2048
2
Edge detection
control
TOD
Selector
3
Timer mode
register D1
(TMD1)
Edge detection
selection register
2 (ESR2)
Timer output
control logic
4
Timer counter D
(TCDL) (TCDU)
4 4
Timer write register D
(TWDL) (TWDU)
Free-running/reload control
Timer mode
register D2
(TMD2)
3
Internal data bus
Figure 61 Block Diagram of Timer D (Free-Running/Reload Timer)
75
Page 78

HD404829R Series
EVND
System
clock
Edge detection
logic
øPER
Input capture
status flag
(ICSF)
Read signal
÷2
÷4
÷8
÷32
÷128
÷512
Prescaler S (PSS)
÷2048
Error control
logic
Selector
Input capture
error flag
(ICEF)
Timer read register D
(TRDL) (TRDU)
4 4
Timer counter D
(TCDL) (TCDU)
Input capture
timer control
Timer D interrupt
request flag
(IFTD)
Overflow
Internal data bus
2
Edge
detection
control
3
Time mode
register D1
(TMD1)
Edge detection
selection register
2 (ESR2)
Timer mode
register D2
(TMD2)
Data bus
Clock line
Signal line
Figure 62 Block Diagram of Timer D (Input Capture Timer)
76
Page 79

HD404829R Series
Registers for Timer D Operation: By using the following registers, timer D operation modes are selected
and the timer D count is read and written.
Timer mode register D1 (TMD1: $010)
Timer mode register D2 (TMD2: $015)
Timer write register D (TWDL: $011, TWDU: $012)
Timer read register D (TRDL: $011, TRDU: $012)
Port mode register C (PMRC: $025)
Detection edge select register 2 (ESR2: $027)
• Timer mode register D1 (TMD1: $010): Four-bit write-only register that selects the free-running/reload
timer function, input clock source, and the prescaler division ratio as shown in figure 63. It is reset to
$0 by MCU reset.
Writing to this register is valid from the second instruction execution cycle after the execution of the
previous timer mode register D1 (TMD1: $010) write instruction. Setting timer D’s initialization by
writing to timer write register D (TWDL: $011, TWDU: $012) must be done after a mode change
becomes valid.
When selecting the input capture timer operation, select the internal clock as the input clock source.
Timer mode register D1 (TMD1: $010)
Bit
Initial value
Read/Write
Bit name
TMD13
0
1
3
0
W
TMD13
Free-running/reload timer selection
Free-running timer
Reload timer
2
0
W
TMD12
TMD11
Figure 63 Timer Mode Register D1 (TMD1)
W
1
0
0
0
W
TMD10
TMD12 TMD10TMD11
0
1
Input clock period and
input clock source
0
1
0
1
0
1
0
1
0
1
0
1
2048t
cyc
512t
cyc
128t
cyc
32t
cyc
8t
cyc
4t
cyc
2t
cyc
R2
/EVND
0
(external event input)
77
Page 80

HD404829R Series
• Timer mode register D2 (TMD2: $015): Four-bit read/write register that selects the timer D output
mode and input capture operation as shown in figure 64. It is reset to $0 by MCU reset.
• Timer write register D (TWDL: $011, TWDU: $012): Write-only register consisting of the lower digit
(TWDL) and the upper digit (TWDU). The operation of timer write register D is basically the same as
that of timer write register B (TWBL: $00A, TWBU: $00B).
• Timer read register D (TRDL: $011, TRDU: $012): Read-only register consisting of the lower digit
(TRDL) and the upper digit (TRDU). The operation of timer read register D is basically the same as
that of timer read register B (TRBL: $00A, TRBU: $00B).
When the input capture timer operation is selected and if the count of timer D is read after a trigger is
input, either the lower or upper digit can be read first.
• Port mode register C (PMRC: $025): Write-only register that selects R20/EVND pin function as shown
in figure 53. It is reset to $0 by MCU reset.
• Detection edge select register 2 (ESR2: $027): Write-only register that selects the detection edge of
signals input to pin EVND as shown in figure 69. It is reset to $0 by MCU reset.
Timer mode register D2 (TMD2: $015)
Bit
Initial value
Read/Write
Bit name
3
0
R/W
TMD23
2
0
R/W
TMD22
1
0
R/W
TMD21
0
0
R/W
TMD20
TMD23
✕: Don’t care
TMD22 TMD20
0
1
TMD21
0
1
✕✕✕
0
1
0
1
0
1
0
1
0
1
0
1
Figure 64 Timer Mode Register D2 (TMD2)
R1
/TOD mode selection
2
R1
TOD
TOD
TOD
—
TOD
R1
R12 port
2
Toggle output
0 output
1 output
Not used
PWM output
Input capture (R1
2
port)
2
78
Page 81

Timer write register D (lower digit) (TWDL: $011)
HD404829R Series
Bit
Initial value
Read/Write
Bit name
3
0
W
TWDL3
2
0
W
TWDL2
1
0
W
TWDL1
0
0
W
TWDL0
Figure 65 Timer Write Register D Lower Digit (TWDL)
Timer write register D (upper digit) (TWDU: $012)
Bit
Initial value
Read/Write
Bit name
3
Undefined
W
TWDU3
2
Undefined
W
TWDU2
1
Undefined
W
TWDU1
0
Undefined
W
TWDU0
Figure 66 Timer Write Register D Upper Digit (TWDU)
Timer read register D (lower digit) (TRDL: $011)
Bit
Initial value
Read/Write
Bit name
3
Undefined
R
TRDL3
2
Undefined
R
TRDL2
1
Undefined
R
TRDL1
0
Undefined
R
TRDL0
Figure 67 Timer Read Register D Lower Digit (TRDL)
Timer read register D (upper digit) (TRDU: $012)
Bit
Initial value
Read/Write
Bit name
3
Undefined
R
TRDU3
2
Undefined
R
TRDU2
1
Undefined
R
TRDU1
0
Undefined
R
TRDU0
Figure 68 Timer Read Register D Upper Digit (TRDU)
79
Page 82

HD404829R Series
Detection edge register 2 (ESR2: $027)
Bit
Initial value
Read/Write
Bit name
ESR23
Note: Both falling and rising edges are detected.
ESR22
0
1
*
ESR23
0
1
0
1
3
0
W
2
0
W
ESR22
EVND detection edge
No detection
Falling-edge detection
Rising-edge detection
Double-edge detection
1
0
W
ESR21
ESR20
**
Figure 69 Detection Edge Select Register 2 (ESR2)
W
0
0
ESR21
0
1
ESR20
0
1
0
1
INT
detection edge
4
No detection
Falling-edge detection
Rising-edge detection
Double-edge detection
80
Page 83
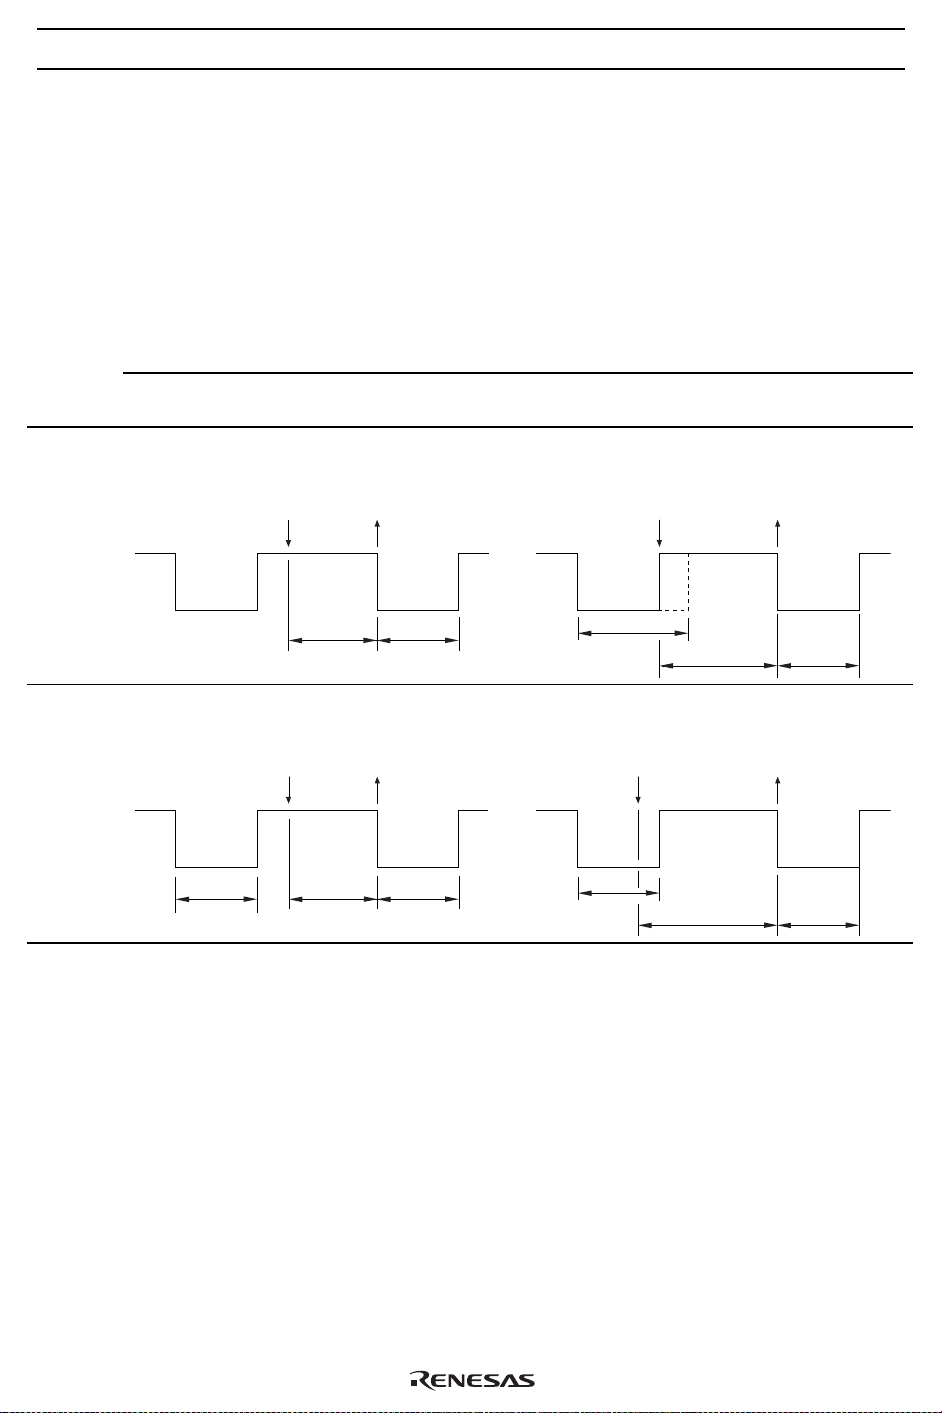
HD404829R Series
Note on Use
When using the timer output as PWM output, note the following point. From the update of the timer write
register untill the occurrence of the overflow interrupt, the PWM output differs from the period and duty
settings, as shown in table 21. The PWM output should therefore not be used until after the overflow
interrupt following the update of the timer write register. After the overflow, the PWM output will have the
set period and duty cycle.
Table 21 PWM Output Following Update of Timer Write Register
PWM Output
Mode
Free
running
Timer Write Register is Updated
during High PWM Output
Timer write
register
rewrite
(set value
is N)
Interrupt
request
generated
Timer Write Register is Updated
during Low PWM Output
Timer write
register
rewrite
(set value
is N)
Interrupt
request
generated
Reload
T × (255 – N) T × (N + 1)
Timer write
register
rewrite
(set value
is N)
Interrupt
request
generated
T × (N' + 1)
T × (255 – N) T × (N + 1)
Timer write
register
rewrite
(set value
is N)
TT × (255 – N)T
T
Interrupt
request
generated
TT × (255 – N)
81
Page 84
HD404829R Series
Serial Interface
The serial interface serially transfers and receives 8-bit data, and includes the following features.
• Multiple transmit clock sources
External clock
Internal prescaler output clock
System clock
• Output level control in idle states
Five registers, an octal counter, and a multiplexer are also configured for the serial interface as follows.
Serial data register (SRL: $006, SRU: $007)
Serial mode register A (SMRA: $005)
Serial mode register B (SMRB: $028)
Miscellaneous register (MIS: $00C)
Octal counter (OC)
Selector
The block diagram of the serial interface is shown in figure 70.
82
Page 85
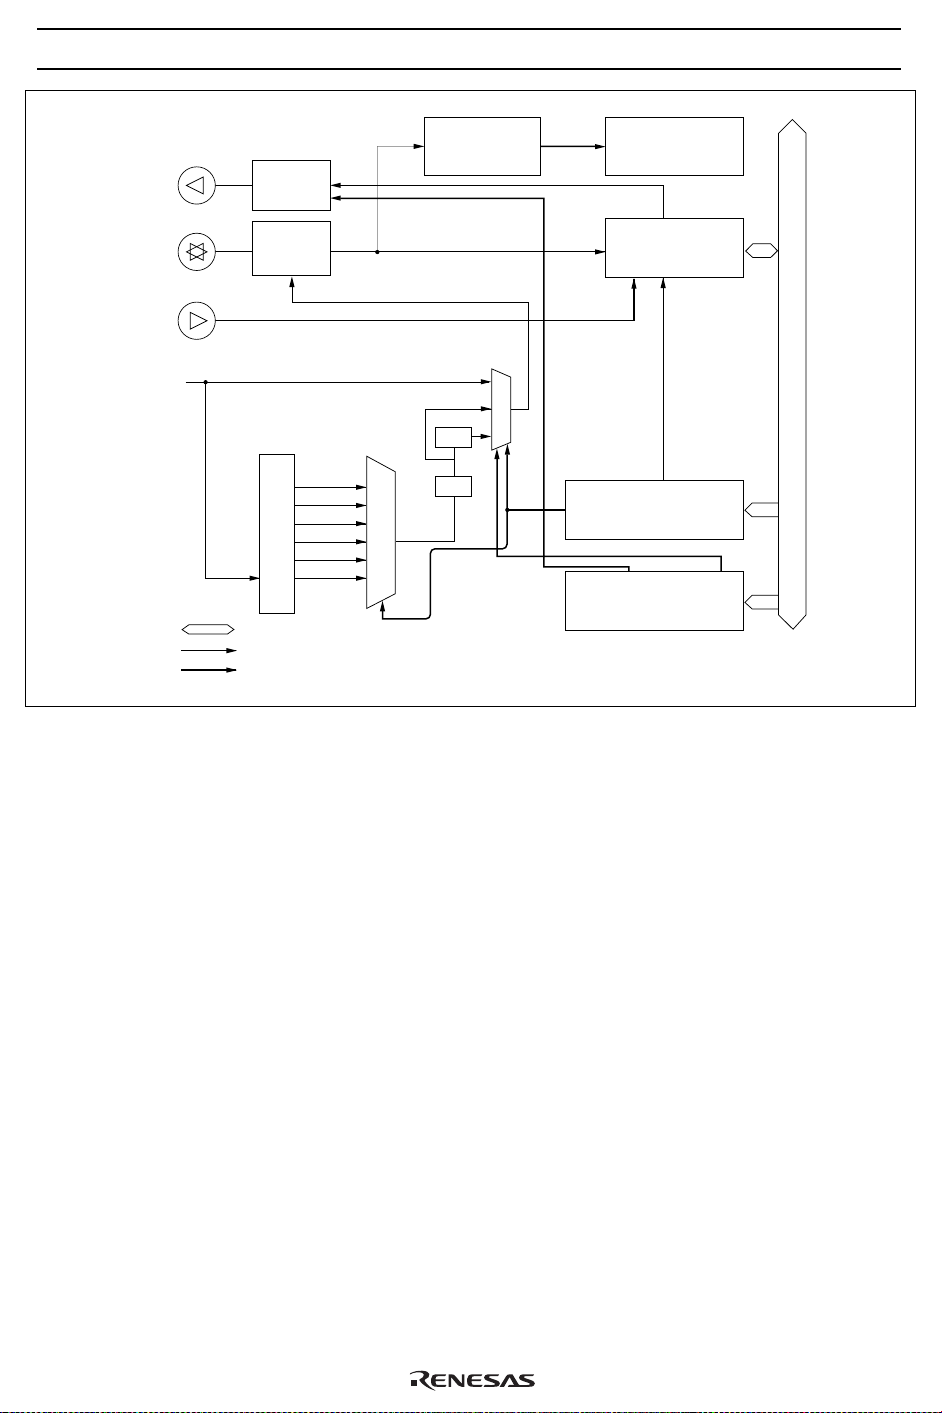
HD404829R Series
SO
SCK
SI
System
clock
Octal
counter (OC)
Idle controll
logic
Selector
Clock
1/2
1/2
Selector
I/O controll
logic
ø
PER
÷2
÷8
÷32
÷128
÷512
÷2048
Prescaler S (PSS)
Data bus
Clock line
Signal line
Serial interrupt
request flag
(IFS)
Serial data
register (SRL/U)
Transfer
control
Serial mode
register A
(SMRA)
Serial mode
register B
(SMRB)
Internal data bus
Figure 70 Block Diagram of Serial Interface
Serial Interface Operation
Selecting and Changing the Operating Mode: table 22 lists the serial interface’s operating modes. To
select an operating mode, use one of these combinations of port mode register A (PMRA: $004) and serial
mode register A (SMRA: $005) settings; to change the operating mode, always initialize the serial interface
internally by writing data to serial mode register A. Note that the serial interface is initialized by writing
data to serial mode register A. Refer to the following Serial Mode Register A section for details.
Pin Setting: The R21/SCK pin is controlled by writing data to serial mode register A (SMRA: $005). The
R22/SI and R23/SO pins are controlled by writing data to port mode register A (PMRA: $004). Refer to the
following Registers for Serial Interface section for details.
Transmit Clock Source Setting: The transmit clock source is set by writing data to serial mode register A
(SMRA: $005) and serial mode register B (SMRB: $028). Refer to the following Registers for Serial
Interface section for details.
Data Setting: Transmit data is set by writing data to the serial data register (SRL: $006, SRU: $007).
Receive data is obtained by reading the contents of the serial data register. The serial data is shifted by the
transmit clock and is input from or output to an external system.
The output level of the SO pin is invalid until the first data is output after MCU reset, or until the output
level control in idle states is performed.
83
Page 86
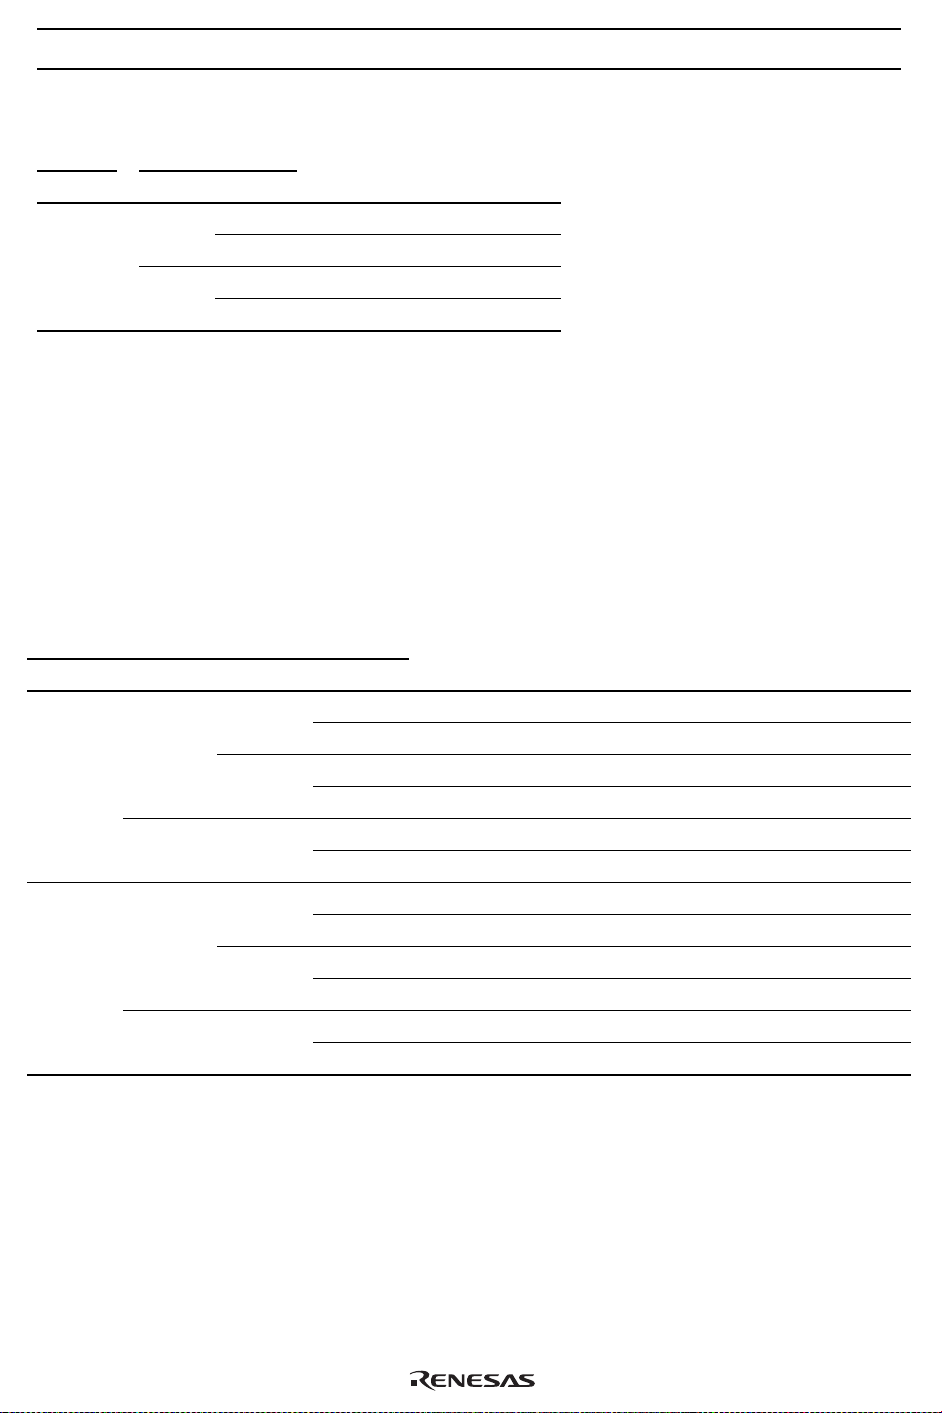
HD404829R Series
Table 22 Serial Interface Operating Modes
SMRA PMRA
Bit 3 Bit 1 Bit 0 Operating Mode
1 0 0 Continuous clock output mode
1 Transmit mode
1 0 Receive mode
1 Transmit/receive mode
Transfer Control: The serial interface is activated by the STS instruction. The octal counter is reset to
000 by this instruction, and it increments at the rising edge of the transmit clock. When the eighth transmit
clock signal is input or when serial transmission/receive is discontinued, the octal counter is reset to 000,
the serial interrupt request flag (IFS: $023, bit 2) is set, and the transfer stops.
When the prescaler output is selected as the transmit clock, the transmit clock frequency is selected as 4t
to 8192t
by setting bits 2 to 0 (SMRA2– SMRA0) of serial mode register A (SMRA: $005) and bit 0
cyc
cyc
(SMRB0) of serial mode register B (SMRB: $028) as listed in table 23.
Table 23 Serial Transmit Clock (Prescaler Output)
SMRB SMRA
Bit 0 Bit 2 Bit 1 Bit 0 Prescaler Division Ratio Transmit Clock Frequency
0000÷ 2048 4096t
1 ÷ 512 1024t
10÷ 128 256t
1 ÷ 32 64t
100÷ 8 16t
1 ÷ 24t
1000÷ 4096 8192t
1 ÷ 1024 2048t
10÷ 256 512t
1 ÷ 64 128t
100÷ 16 32t
1 ÷ 48t
cyc
cyc
cyc
cyc
cyc
cyc
cyc
cyc
cyc
cyc
cyc
cyc
Operating States: The serial interface has the following operating states; transitions between them are
shown in figure 71.
STS wait state
Transmit clock wait state
Transfer state
Continuous clock output state (only in internal clock mode)
84
Page 87

HD404829R Series
• STS wait state: The serial interface enters STS wait state by MCU reset (00, 10 in figure 71). In STS
wait state, the serial interface is initialized and the transmit clock is ignored. If the STS instruction is
then executed (01, 11), the serial interface enters transmit clock wait state.
• Transmit clock wait state: Transmit clock wait state is between the STS execution and the falling edge
of the first transmit clock. In transmit clock wait state, input of the transmit clock (02, 12) increments
the octal counter, shifts the serial data register, and enters the serial interface in transfer state. However,
note that if continuous clock output mode is selected in internal clock mode, the serial interface does not
enter transfer state but enters continuous clock output state (17).
The serial interface enters STS wait state by writing data to serial mode register A (SMRA: $005) (04,
14) in transmit clock wait state.
• Transfer state: Transfer state is between the falling edge of the first clock and the rising edge of the
eighth clock. In transfer state, the input of eight clocks or the execution of the STS instruction sets the
octal counter to 000, and the serial interface enters another state. When the STS instruction is executed
(05, 15), transmit clock wait state is entered. When eight clocks are input, transmit clock wait state is
entered (03) in external clock mode, and STS wait state is entered (13) in internal clock mode. In
internal clock mode, the transmit clock stops after outputting eight clocks.
In transfer state, writing data to serial mode register A (SMRA: $005) (06, 16) initializes the serial
interface, and STS wait state is entered.
If the state changes from transfer to another state, the serial interrupt request flag (IFS: $023, bit 2) is set
by the octal counter that is reset to 000.
• Continuous clock output state (only in internal clock mode): Continuous clock output state is entered
only in internal clock mode. In this state, the serial interface does not transmit/
receive data but only outputs the transmit clock from the SCK pin.
When bits 1 and 0 (PMRA1, PMRA0) of port mode register A (PMRA: $004) are 00 in transmit clock
wait state and if the transmit clock is input (17), the serial interface enters continuous clock output state.
If serial mode register A (SMRA: $005) is written to in continuous clock output mode (18), STS wait
state is entered.
85
Page 88
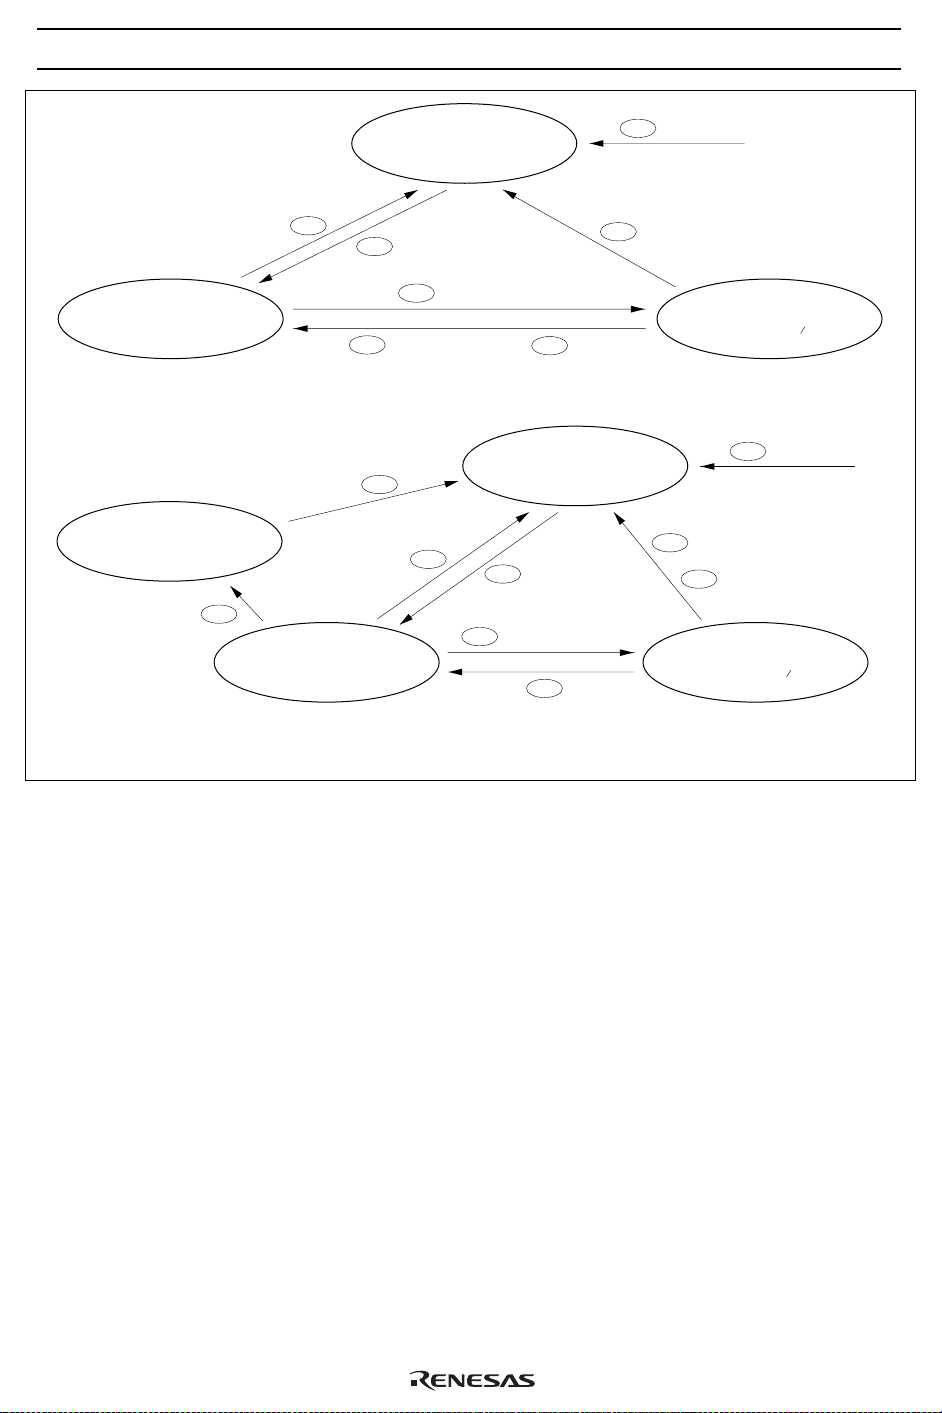
HD404829R Series
External clock mode
SMRA write
Transmit clock wait state
(Octal counter = 000)
Internal clock mode
Continuous clock output state
(PMRA 0, 1 = 00)
Transmit clock 17
(Octal counter = 000,
transmit clock disabled)
04
01
03
8 transmit clocks
SMRA write
18
SMRA write
Transmit clock wait state
(Octal counter = 000)
STS wait state
STS instruction
Transmit clock
02
STS instruction (IFS 1)
(Octal counter = 000,
transmit clock disabled)
14
11
Transmit clock
12
STS instruction (IFS 1)
06
05
←
STS wait state
STS instruction
15
←
00
MCU reset
SMRA write (IFS 1)
Transfer state
(Octal counter = 000)
8 transmit clocks
13
SMRA write (IFS 1)
16
Transfer state
(Octal counter = 000)
←
MCU reset10
←
Note: Refer to the Operating States section for the corresponding encircled numbers.
Figure 71 Serial Interface State Transitions
Output Level Control in Idle States: In idle states, that is, STS wait state and transmit clock wait state,
the output level of the SO pin can be controlled by setting bit 1 (SMRB1) of serial mode register B (SMRB:
$028) to 0 or 1. The output level control example is shown in figure 72. Note that the output level cannot
be controlled in transfer state.
86
Page 89
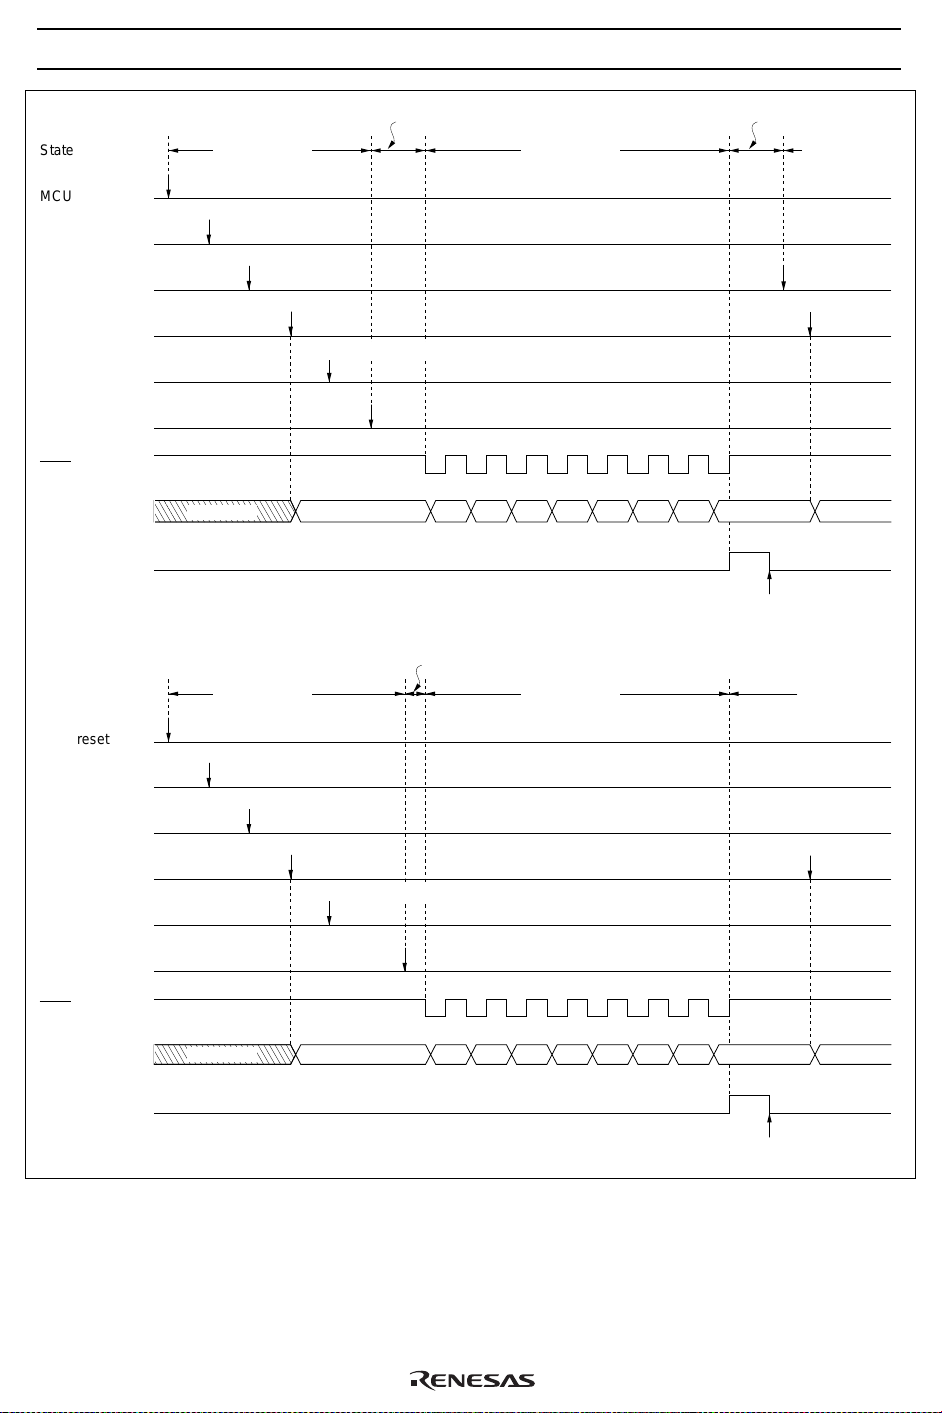
HD404829R Series
State
MCU reset
PMRA write
SMRA write
SMRB write
SRL, SRU write
STS instruction
SCK pin (input)
SO pin
IFS
State
Transmit clock
wait state
STS wait state
Port selection
External clock selection
Output level control in
Undefined LSBidle idleMSB
STS wait state Transfer state
idle states
Data write for transmission
External clock mode
Transmit clock
wait state
Transfer state
Output level control in
Flag reset at transfer completion
Transmit clock
wait state
STS wait state
Dummy write for
state transition
idle states
STS wait state
MCU reset
PMRA write
SMRA write
SMRB write
SRL, SRU write
STS instruction
SCK pin (output)
SO pin
IFS
Port selection
Internal clock selection
Output level control in
Undefined MSB
idle states
Data write for transmission
idle idleLSB
Internal clock mode
Flag reset at transfer completion
Output level control in
Figure 72 Example of Serial Interface Operation Sequence
idle states
87
Page 90
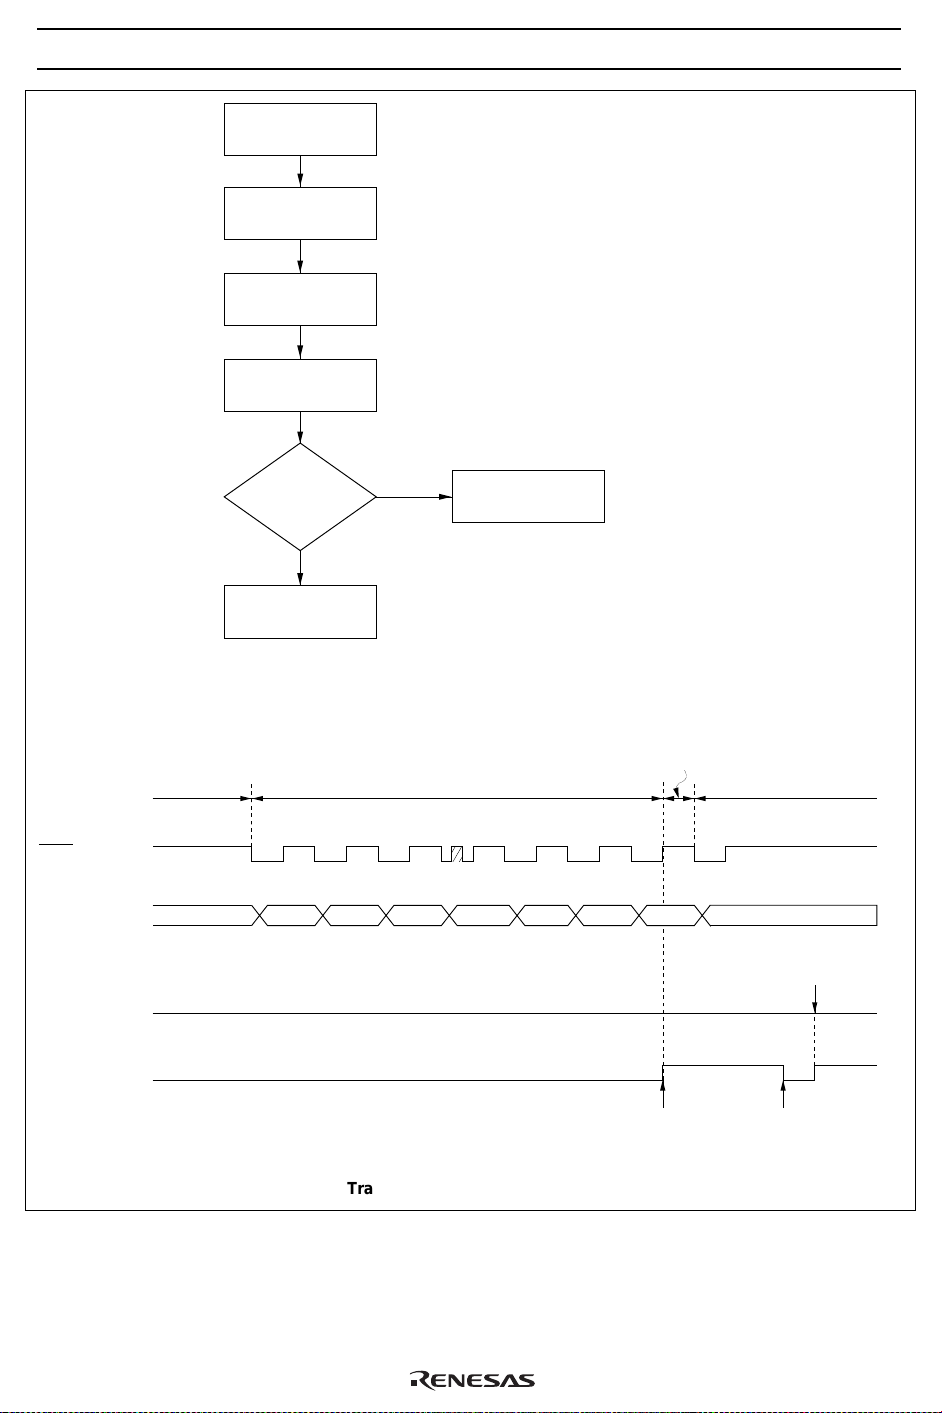
HD404829R Series
Transfer completion
Interrupts inhibited
Transmit clock error detection flowchart
←
(IFS 1)
←
IFS 0
SMRA write
IFS = 1?
No
Normal
termination
Yes
Transmit clock
error processing
State
SCK pin (input)
SMRA write
IFS
Transmit clock
wait state
Transmit clock wait state
Transfer state Transfer state
Noise
12345678
Transfer state has been
entered by the transmit clock
error. When SMRA is written,
IFS is set.
Flag set because octal
counter reaches 000
Transmit clock error detection procedure
Flag reset at
transfer completion
Figure 73 Transmit Clock Error Detection
88
Page 91

HD404829R Series
Transmit Clock Error Detection (In External Clock Mode): The serial interface will malfunction if a
spurious pulse caused by external noise conflicts with a normal transmit clock during transfer. A transmit
clock error of this type can be detected as shown in figure 73.
If more than eight transmit clocks are input in transfer state, at the eighth clock including a spurious pulse
by noise, the octal counter reaches 000, the serial interrupt request flag (IFS: $023, bit 2) is set, and
transmit clock wait state is entered. At the falling edge of the next normal clock signal, the transfer state is
entered. After the transfer completion processing is performed and IFS is reset, writing to serial mode
register A (SMRA: $005) changes the state from transfer to STS wait. At this time IFS is set again, and
therefore the error can be detected.
Notes on Use:
• Initialization after writing to registers: If port mode register A (PMRA: $004) is written to in transmit
clock wait state or in transfer state, the serial interface must be initialized by writing to serial mode
register A (SMRA: $005) again.
• Serial interrupt request flag (IFS: $023, bit 2) set: If the state is changed from transfer to another by
writing to serial mode register A (SMRA: $005) or executing the STS instruction during the first low
pulse of the transmit clock, the serial interrupt request flag is not set. To set the serial interrupt request
flag, serial mode register A write or STS instruction execution must be programmed to be executed after
confirming that the SCK pin is at 1, that is, after executing the input instruction to port R2.
Registers for Serial Interface
The serial interface operation is selected, and serial data is read and written by the following registers.
Serial Mode Register A (SMRA: $005)
Serial Mode Register B (SMRB: $028)
Serial Data Register (SRL: $006, SRU: $007)
Port Mode Register A (PMRA: $004)
Miscellaneous Register (MIS: $00C)
Serial Mode Register A (SMRA: $005): This register has the following functions (figure 74).
• R21/SCK pin function selection
• Transfer clock selection
• Prescaler division ratio selection
• Serial interface initialization
Serial mode register A (SMRA: $005) is a 4-bit write-only register. It is reset to $0 by MCU reset.
A write signal input to serial mode register A (SMRA: $005) discontinues the input of the transmit clock to
the serial data register and octal counter, and the octal counter is reset to 000. Therefore, if a write is
performed during data transfer, the serial interrupt request flag (IFS: $023, bit 2) is set.
Written data is valid from the second instruction execution cycle after the write operation, so the STS
instruction must be executed at least two cycles after that.
89
Page 92
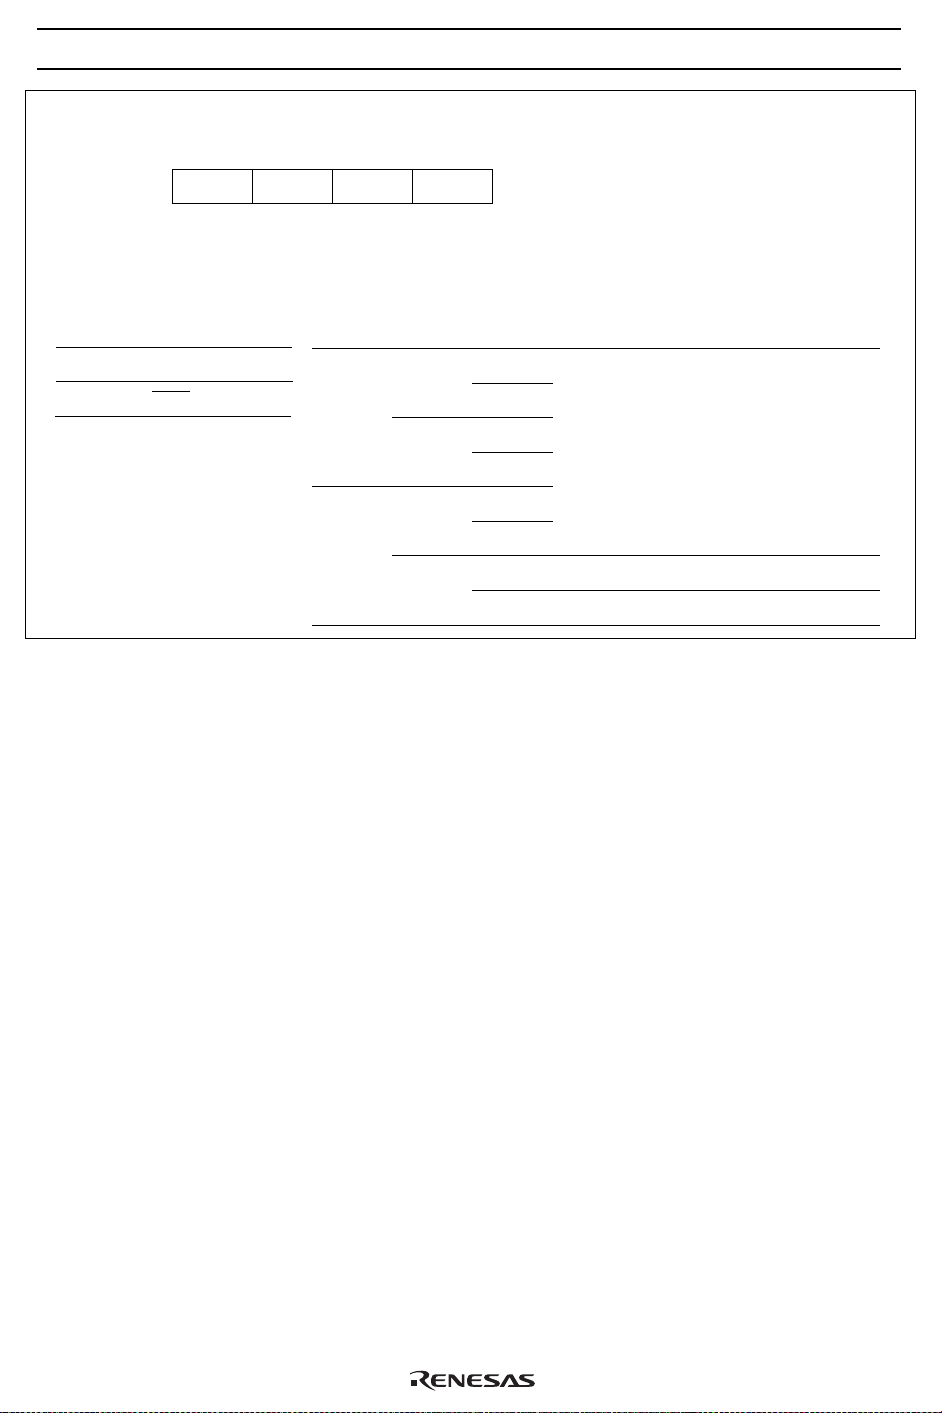
HD404829R Series
Serial mode register A (SMRA: $005)
Bit
Initial value
Read/Write
Bit name
SMRA3
0
1
3
0
W
SMRA3
R21/SCK
mode selection
R2
1
SCK
SMRA2
2
0
W
1
0
W
SMRA1
SMRA2 SMRA0SMRA1
0
1
0
0
W
SMRA0
0
1
0
1
SCK
Output
0
1
0
1
0
1
Output
0
Input
1
Clock source
Prescaler
System clock
External clock
Prescaler
division ratio
Refer to
table 23
—
—
Figure 74 Serial Mode Register A (SMRA)
Serial Mode Register B (SMRB: $028): This register has the following functions (figure 75).
• Prescaler division ratio selection
• Output level control in idle states
Serial mode register B is a 2-bit write-only register. It cannot be written during data transfer.
By setting bit 0 (SMRB0) of this register, the prescaler division ratio is selected. Only bit 0 (SMRB0) can
be reset to 0 by MCU reset. By setting bit 1 (SMRB1), the output level of the SO pin is controlled in idle
states. The output level changes at the same time that SMRB1 is written to.
90
Page 93

Serial mode register B (SMRB: $028)
HD404829R Series
Bit
Initial value
Read/Write
Bit name
SMRB1
0
1
3
—
—
Not used
Output level control in idle states
Low level
High level
2
—
—
Not used
1
Undefined
W
SMRB1
0
0
W
SMRB0
SMRB0
0
1
Transmit clock division ratio
Prescaler output divided by 2
Prescaler output divided by 4
Figure 75 Serial Mode Register B (SMRB)
Serial Data Register (SRL: $006, SRU: $007): This register has the following functions (figures 76 and
77).
• Transmission data write and shift
• Receive data shift and read
Writing data in this register is output from the SO pin, LSB first, synchronously with the falling edge of the
transmit clock; data is input, LSB first, through the SI pin at the rising edge of the transmit clock.
Input/output timing is shown in figure 78.
Data cannot be read or written during serial data transfer. If a read/write occurs during transfer, the
accuracy of the resultant data cannot be guaranteed.
Serial data register (lower digit) (SRL: $006)
Bit
Initial value
Read/Write
Bit name
3
Undefined
R/W
SR3
2
Undefined
R/W
SR2
1
Undefined
R/W
SR1
Undefined
Figure 76 Serial Data Register (SRL)
Serial data register (upper digit) (SRU: $007)
Bit
Initial value
Read/Write
Bit name
3
Undefined
R/W
SR7
2
Undefined
R/W
SR6
1
Undefined
R/W
SR5
Undefined
Figure 77 Serial Data Register (SRU)
0
R/W
SR0
0
R/W
SR4
91
Page 94
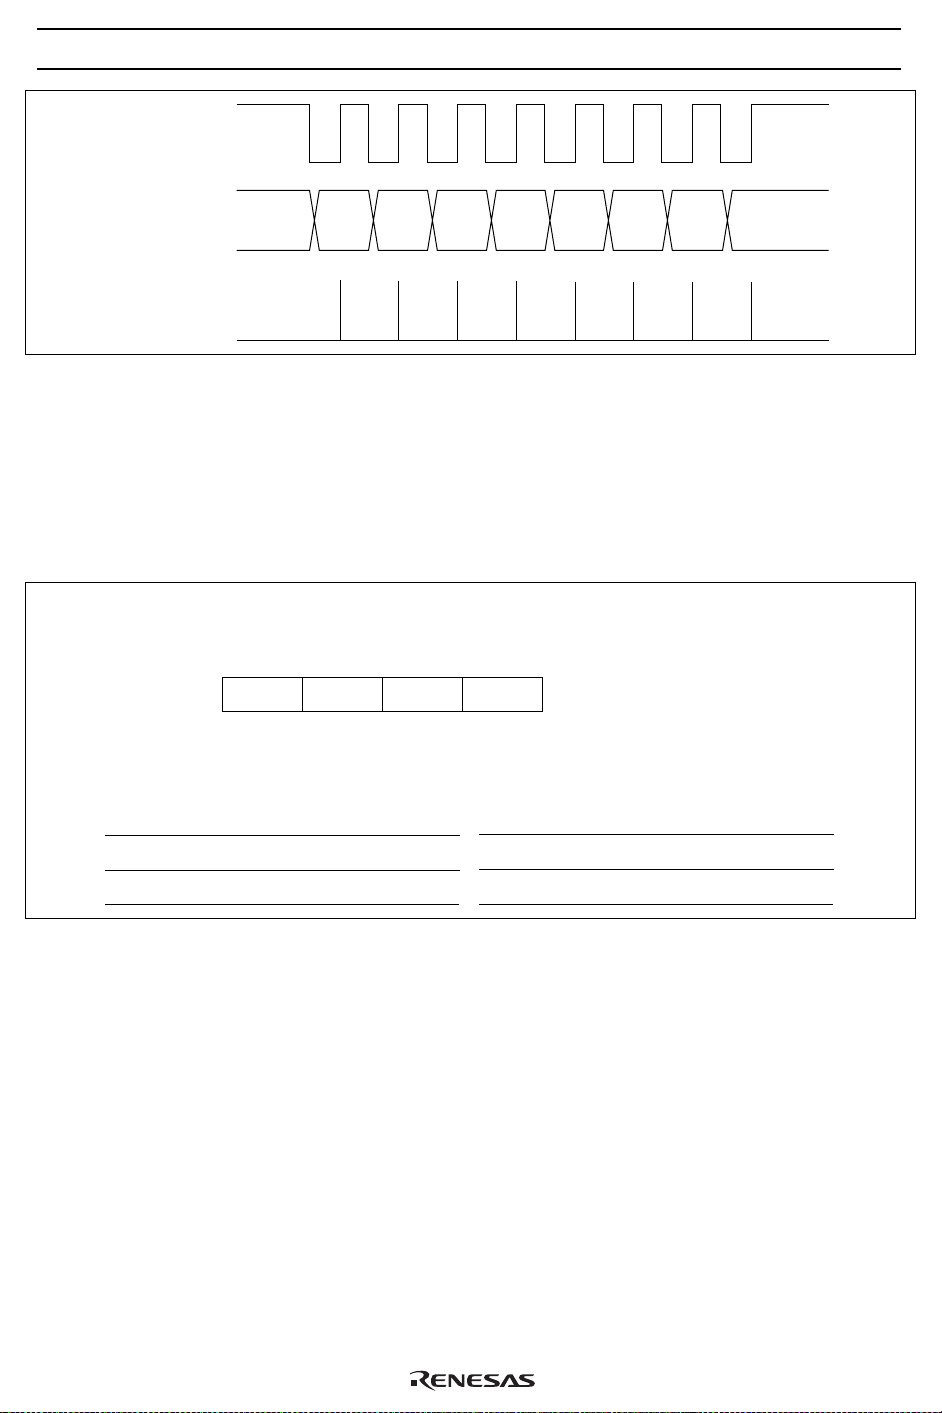
HD404829R Series
Transmit clock
12345678
Serial output
data
Serial input data
latch timing
Port Mode Register A (PMRA: $004): This register has the following functions (figure 79).
• R22/SI pin function selection
• R23/SO pin function selection
Port mode register A (PMRA: $004) is a 2-bit write-only register, and is reset to $0 by MCU reset.
Port mode register A (PMRA: $004)
LSB MSB
Figure 78 Serial Interface Output Timing
Bit
Initial value
Read/Write
Bit name
PMRA1
0
1
3
—
—
Not used
R22/SI mode selection
R2
2
SI
2
—
—
Not used
Figure 79 Port Mode Register A (PMRA)
1
0
W
PMRA1
0
0
W
PMRA0
PMRA0
0
1
R23/SO mode selection
R2
3
SO
92
Page 95

HD404829R Series
Miscellaneous Register (MIS: $00C): This register has the following function (figure 80).
• R23/SO pin PMOS control
Miscellaneous register (MIS: $00C) is a 4-bit write-only register and is reset to $0 by MCU reset.
Miscellaneous register (MIS: $00C)
Bit
Initial value
Read/Write
Bit name
MIS3
0
1
MIS2
0
1
3
0
W
MIS3
Pull-up MOS on/off selection
Off
On
R23/SO PMOS on/off selection
On
Off
2
0
W
MIS2
1
0
W
MIS1
0
0
W
MIS0
MIS1
MIS0
0
1
0
1
0
1
t
RC
0.12207 ms
0.24414 ms
7.8125 ms
31.25 ms
Not used
Figure 80 Miscellaneous Register (MIS)
A/D Converter
The MCU has a built-in A/D converter that uses a successive approximation method with a resistor ladder.
It can measure four analog inputs with 8-bit resolution. As shown in the block diagram of figure 81, the
A/D converter has a 4-bit A/D mode register, a 1-bit A/D start flag, and a 4-bit plus 4-bit A/D data register.
93
Page 96
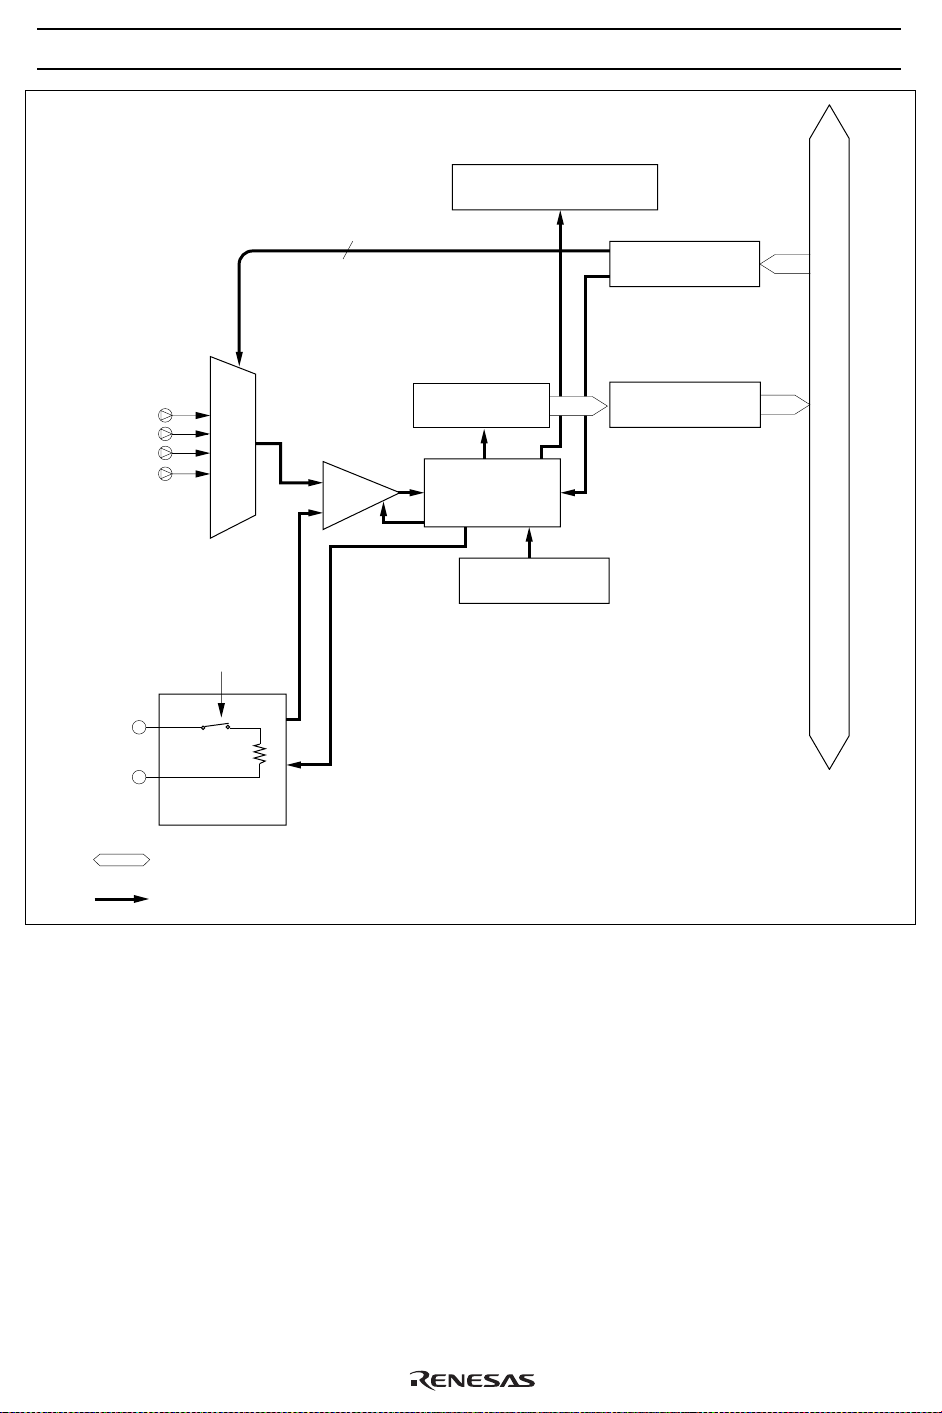
HD404829R Series
A/D interrupt request flag
(IFAD)
AN
0
AN
1
AN
2
AN
3
Off in stop, watch,
and subactive
AV
CC
AV
SS
Selector
modes
Resistance ladder
2
+
COMP
–
Encoder
A/D control
logic
A/D start flag
(ADSF)
A/D mdoe register
(AMR)
A/D data register
(ADR)
Conversion time
control
Internal data bus
Data bus
Signal line
Figure 81 Block Diagram of A/D Converter
A/D Mode Register (AMR: $016): Four-bit write-only register which selects the A/D conversion period
and indicates analog input pin information. Bit 0 of the A/D mode register selects the A/D conversion
period, and bits 3 and 2 select a channel, as shown in figure 82.
94
Page 97

A/D mode register (AMR: $016)
HD404829R Series
Bit
Initial value
Read/Write
Bit name
AMR3
0
0
1
1
AMR2
0
1
0
1
3
0
W
AMR3
2
0
W
AMR2
Analog input selection
AN
0
AN
1
AN
2
AN
3
1
—
—
Not used
0
0
W
AMR0
AMR0
Conversion time
0
1
34t
67t
cyc
cyc
Figure 82 A/D Mode Register (AMR)
A/D Data Register (ADRL: $017, ADRU: $018): Eight-bit read-only register consisting of a 4-bit lower
digit and 4-bit upper digit. This register is not cleared by reset. After the completion of A/D conversion,
the resultant eight-bit data is held in this register until the start of the next conversion (figures 83, 84, and
85).
ADRU: $018 ADRL: $017
3210
3210
MSB LSB
Figure 83 A/D Data Registers (ADRU, ADRL)
Bit 0Bit 7
95
Page 98
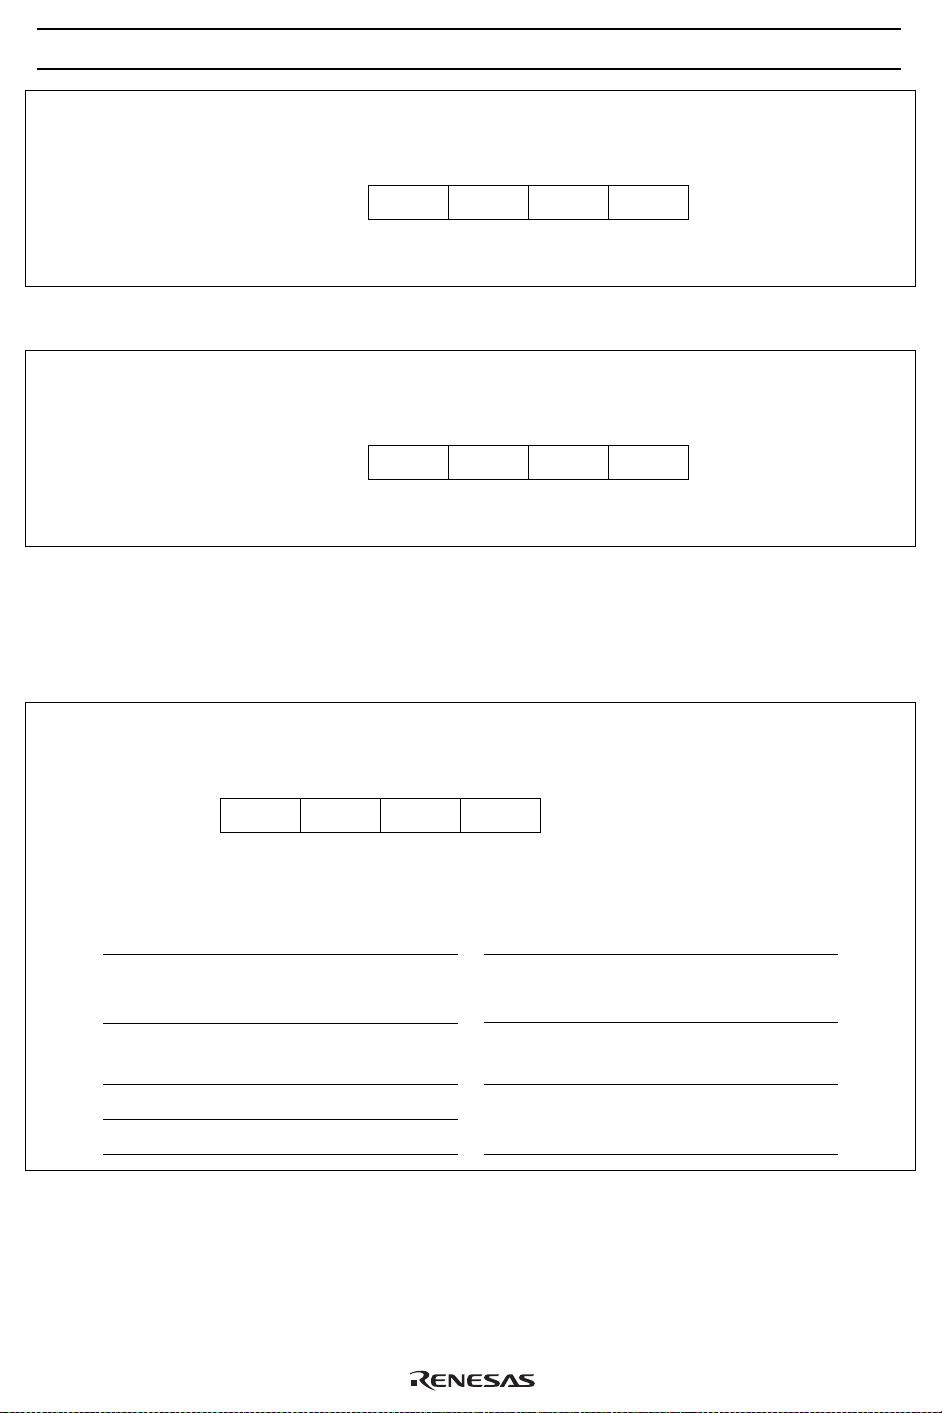
HD404829R Series
A/D data register (lower digit) (ADRL: $017)
Bit
Initial value
Read/Write
Bit name
3
0
R
ADRL3
2
0
R
ADRL2
1
0
R
ADRL1
0
0
R
ADRL0
Figure 84 A/D Data Register Lower Digit (ADRL)
A/D data register (upper digit) (ADRU: $018)
Bit
Initial value
Read/Write
Bit name
3
1
R
ADRU3
2
0
R
ADRU2
ADRU1
1
0
R
0
0
R
ADRU0
Figure 85 A/D Data Register Upper Digit (ADRU)
A/D Start Flag (ADSF: $020, Bit 2): One-bit flag that initiates A/D conversion when set to 1. At the
completion of A/D conversion, the converted data is stored in the A/D data register and the A/D start flag is
cleared. Refer to figure 86.
A/D start flag (ADSF: $020, bit 2)
Bit
Initial value
Read/Write
Bit name
Refer to the description of operating
modes
1
0
3
0
R/W
DTON
DTON
ADSF (A/D start flag)
A/D conversion started
A/D conversion completed
2
0
R/W
ADSF
Figure 86 A/D Start Flag (ADSF)
1
0
R/W
WDON
0
0
R/W
LSON
WDON
Refer to the description of timers
LSON
Refer to the description of operating
modes
96
Page 99
HD404829R Series
Note on Use: Use the SEM and SEMD instructions to write data to the A/D start flag (ADSF: $020, bit 2),
but make sure that the A/D start flag is not written to during A/D conversion. Data read from the A/D data
register (ADRL: $017, ADRU: $018) during A/D conversion cannot be guaranteed.
The A/D converter does not operate in the stop, watch, and subactive modes because of the OSC clock.
During these low-power dissipation modes, current through the resistor ladder is cut off to decrease the
power input.
97
Page 100

HD404829R Series
LCD Controller/Driver
The MCU has an LCD controller and driver which drive 4 common signal pins and 52 segment pins. The
controller consists of a RAM area in which display data is stored, a display control register (LCR: $01B),
and a duty-cycle/clock-control register (LMR: $01C) (figure 87).
Four duty cycles and the LCD clock are programmable, and a built-in dual-port RAM ensures that display
data can be automatically transmitted to the segment signal pins without program intervention. If a 32-kHz
oscillation clock is selected as the LCD clock source, the LCD can even be used in watch mode, in which
the system clock stops.
V
COM1
COM2
COM3
COM4
Common
signal
output
circuit
CC
V
1
V
2
V
3
GND
Internal LCD power supply switch
LCD power supply
control circuit
Pin control
4
LCD control
register
(LCR)
LCD output
register 1
(LOR1)
SEG1
SEG4
SEG5
SEG8
SEG9
SEG20
SEG21
SEG52
Segment
signal
output
circuit
Note: Pin function switching circuit
Clock
CL0
2
52
2
Selector
CL1
4
3
Display
control
Display data
Duty
selection
CL2
CL3
LCD output
register 2
(LOR2)
LCD output
register 3
(LOR3)
Internal data bus
Dual-port
display RAM
(52 digits)
2
LCD mode
register
(LMR)
Data bus
Clock line
Signal line
98
Figure 87 LCD Controller/Driver Block Diagram
 Loading...