

Page 1
CXD2598Q
CD Digital Signal Processor with Built-in Digital Servo and DAC
Description
The CXD2598Q is a digital signal processor LSI for
CD players. This LSI incorporates a digital servo,
digital filter, 1-bit DAC and analog low-pass filter on a
single chip.
Features
• All digital signal processing during playback is
performed with a single chip
• Highly integrated mounting possible due to a built-
in RAM
Digital Signal Processor (DSP) Block
• Playback mode supporting CAV (Constant Angular
Velocity)
• Frame jitter free
• 0.5× to 4× continuous playback possible
• Allows relative rotational velocity readout
• Wide capture range playback mode
• Spindle rotational velocity following method
• Supports normal-speed to 4× speed playback
• Supports variable pitch playback
• The bit clock, which strobes the EFM signal, is
generated by the digital PLL.
• EFM data demodulation
• Enhanced EFM frame sync signal protection
• Refined super strategy-based powerful error correction
C1: double correction, C2: quadruple correction
Supported during 4× speed playback
• Noise reduction during track jumps
• Auto zero-cross mute
• Subcode demodulation and Sub-Q data error detection
• Digital spindle servo
• 16-bit traverse counter
• Asymmetry correction circuit
• CPU interface on serial bus
• Error correction monitor signal, etc. output from a
new CPU interface
• Servo auto sequencer
• Fine search performs track jumps with high accuracy
• Digital audio interface outputs
• Digital level meter, peak meter
• Bilingual compatible
• VCO control mode
• CD TEXT data demodulation
Digital Servo (DSSP) Block
• Microcomputer software-based flexible servo control
• Offset cancel function for servo error signal
• Auto gain control function for servo loop
• E:F balance, focus bias adjustment functions
• Surf jump function supporting micro two-axis
• Tracking filter: 6 stages
Focus filter: 5 stages
Digital Filter, DAC and Analog Low-Pass Filter Blocks
• DBB (digital bass boost) function
• Digital de-emphasis
• Digital attenuation
• 8fs oversampling digital filter
• Adoption of tertiary ∆∑ noise shaper
• S/N: 100dB or more (master clock: 384Fs, typ.)
Logical value: 109dB
• THD + N: 0.007% or less (master clock: 384Fs, typ.)
• Rejection band attenuation: –60dB or less
• Double-speed playback supported
Applications
CD players
Structure
Silicon gate CMOS IC
Absolute Maximum Ratings
• Supply voltage VDD –0.3 to +7.0 V
• Input voltage VI –0.3 to +7.0 V
(Vss – 0.3V to VDD + 0.3V)
• Output voltage VO –0.3 to +7.0 V
(Vss – 0.3V to VDD + 0.3V)
• Storage temperature Tstg –40 to +125 °C
• Supply voltage difference
VSS – AVSS –0.3 to +0.3 V
VDD – AVDD –0.3 to +0.3 V
Note) AVDD includes XVDD and AVSS includes XVSS.
Recommended Operating Conditions
• Supply voltage VDD 2.7 to 5.5 V
• Operating temperature Topr –20 to +75 °C
Note) The VDD for the CXD2598Q varies according
to the playback speed selection.
I/O Pin Capacitance
• Input capacitance CI 11 (Max.) pF
• Output capacitance CO 11 (Max.) pF
• I/O capacitance CI/O 11 (Max.) pF
Note) Measurement conditions VDD = VI = 0V
fM = 1MHz
– 1 –
E97Y14-PS
Sony reserves the right to change products and specifications without prior notice. This information does not convey any license by
any implication or otherwise under any patents or other right. Application circuits shown, if any, are typical examples illustrating the
operation of the devices. Sony cannot assume responsibility for any problems arising out of the use of these circuits.
100 pin QFP (Plastic)
Playback speed
CD-DSP block
DAC block
4×
4.75 to 5.25
2×
3.0 to 5.5 4.5 to 5.5
1×
2.7 to 5.5 2.7 to 5.5
VDD[V]
Page 2
– 2 –
CXD2598Q
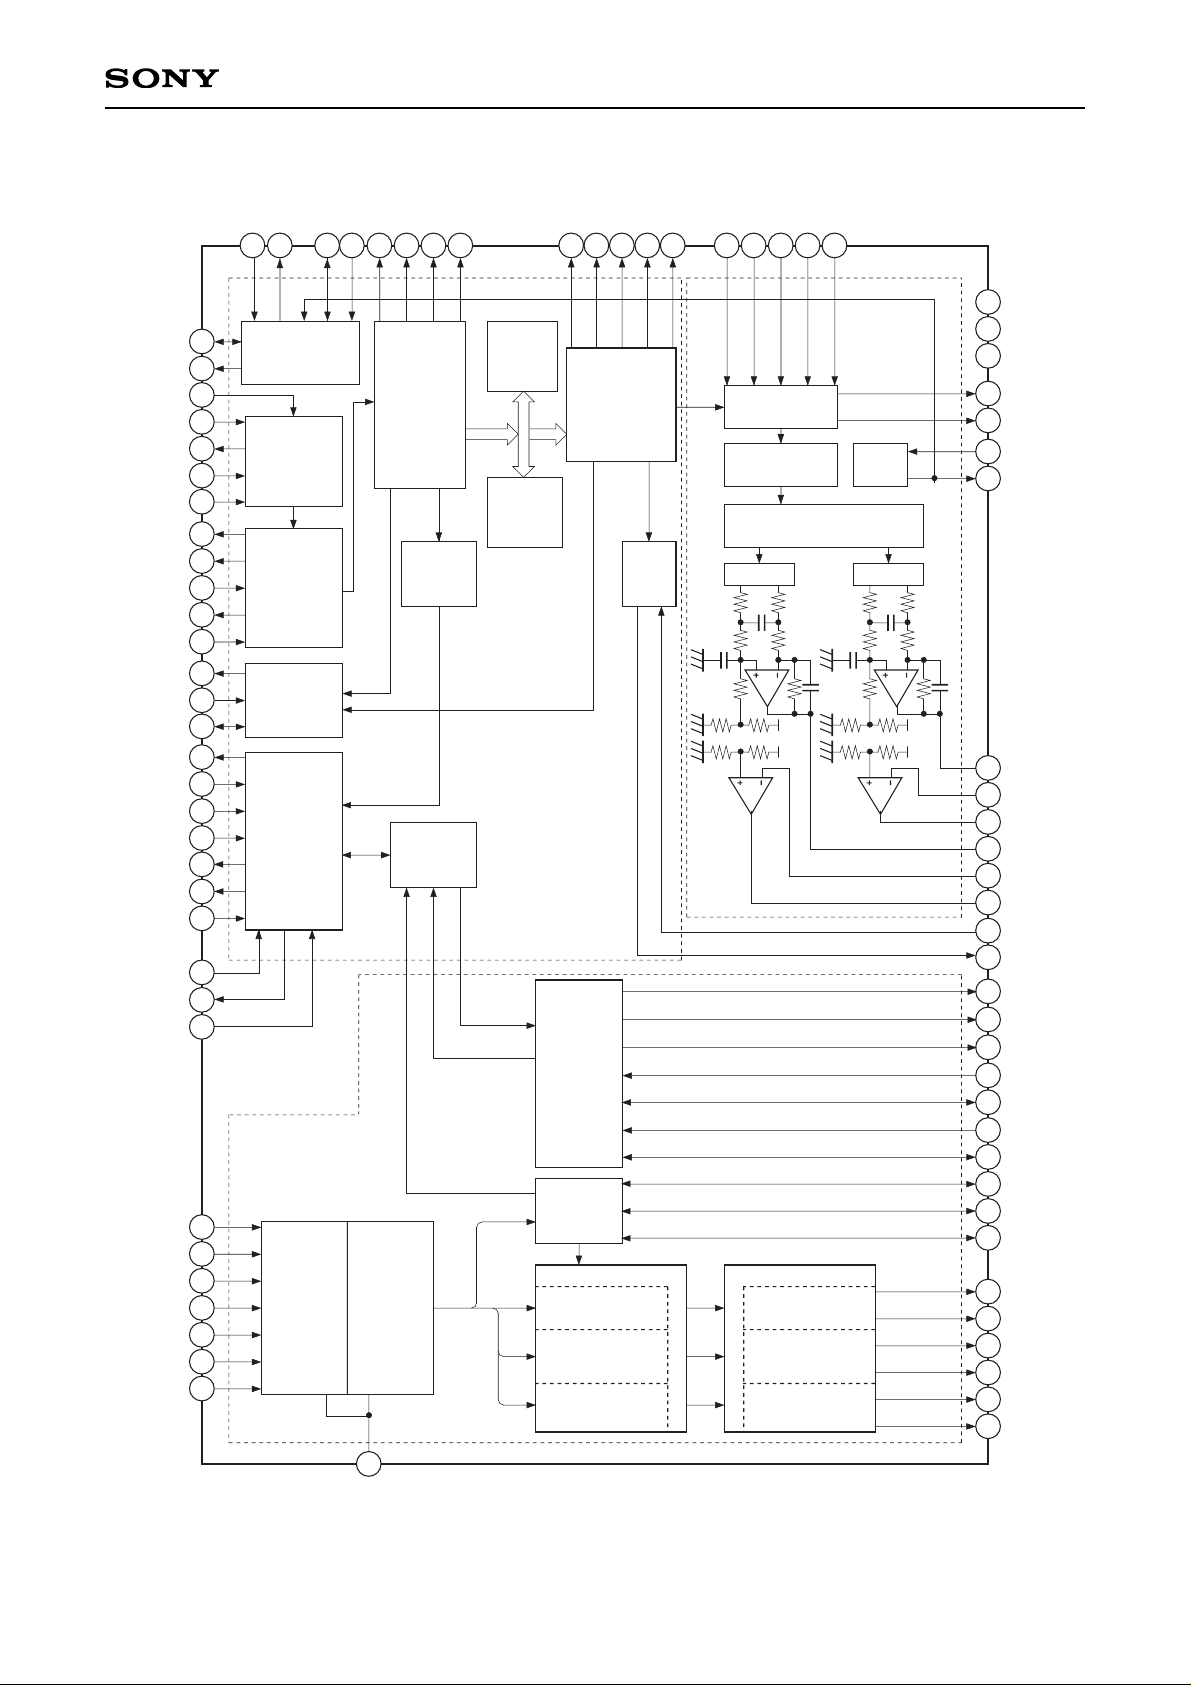
Block Diagram
PWM PWM
AOUT1
AIN1
LOUT1
AOUT2
AIN2
LOUT2
3rd-Order
Noise Shaper
Over Sampling
Digital Filter
Serial-In
Interface
LMUT
RMUT
XTAO
XTAI
Timing
Logic
XRST
TEST
TES1
D/A
Interface
DOUT
EFM
demodulator
Error
Corrector
32K
RAM
Digital
OUT
Sub Code
Processor
Clock
Generator
Asymmetry
Corrector
Digital
PLL
CPU
Interface
Servo
Auto
Sequencer
Signal Processor Block
DAC Block
PCMDI
BCK
PCMD
LRCK
C2PO
WFCK
EMPH
GFS
XUGF
XTSL
RFAC
ASYI
ASYO
BIAS
FSTIO
FILO
FILI
PCO
CLTV
MDP
PWMI
SENS
DATA
XLAT
CLOK
SCOR
SBSO
EXCK
Servo Block
SERVO
Interface
SCLK
COUT
SSTP
ATSK
MIRR
DFCT
FOK
MIRR
DFCT
FOK
SERVO DSP
FOCUS SERVO
TRACKING
SERVO
SLED SERVO
PWM GENERATOR
FOCUS PWM
GENERATOR
TRACKING PWM
GENERATOR
SLED PWM
GENERATOR
FFDR
FRDR
TFDR
TRDR
SFDR
SRDR
RFDC
CE
TE
SE
FE
VC
IGEN
OPAmp
Analog SW
A/D
Converter
ADIO
BCKI
SYSM
LRCKI
EMPHI
WDCK
VPCO
V16M
VCTL
XPCK
C4M
SQSO
SQCK
LOCK
Digital
CLV
ASYE
SCSY
XOLT
SOCK
SOUT
MD2
Page 3

– 3 –
CXD2598Q
Pin Configuration
V
DD
V
SS
SOUT
SOCK
XOLT
SQSO
SQCK
SCSY
SBSO
EXCK
XRST
SYSM
DATA
XLAT
CLOK
SENS
SCLK
ATSK
WFCK
XUGF
XPCK
GFS
C2PO
SCOR
C4M
WDCK
COUT
MIRR
V
SS
V
DD
PCMDI
PCMD
LRCKI
LRCK
VDDASYE
DOUT
MD2
V
SS
VPCO
V16M
VCTL
BIAS
AV
DD
3
PCO
FILI
FILO
CLTV
AV
SS
3
RFAC
ASYI
ASYO
AV
DD
0
IGEN
AV
SS
0
ADIO
RFDC
CE
TE
SE
FE
VC
XTSL
TES1
TEST
VSS
VDD
FRDR
FFDR
TRDR
TFDR
SRDR
SFDR
FSTIO
SSTP
MDP
LOCK
PWMI
FOK
DFCT
40
39
38
37
36
35
34
31
32
33
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
57
58
59
60
70
69
68
67
63
64
65
66
61
62
71
72
73
74
75
76
77
78
79
80
2
3
4
5
6
7
8
9
10
11
12
13
14 15
16
17
18
19
20
21
22
23
24
25
26
27
28
29
30
1
81
82
83
84
88
87
86
85
89
90
100
99
98
97
96
95
94
91
92
93
BCK
BCKI
EMPH
EMPHI
XV
DD
XTAI
XTAO
XV
SS
AVDD1
AOUT1
AIN1
LOUT1
AVSS1
AVSS2
LOUT2
AIN2
AOUT2
AVDD2
RMUT
LMUT
Page 4
– 4 –
CXD2598Q
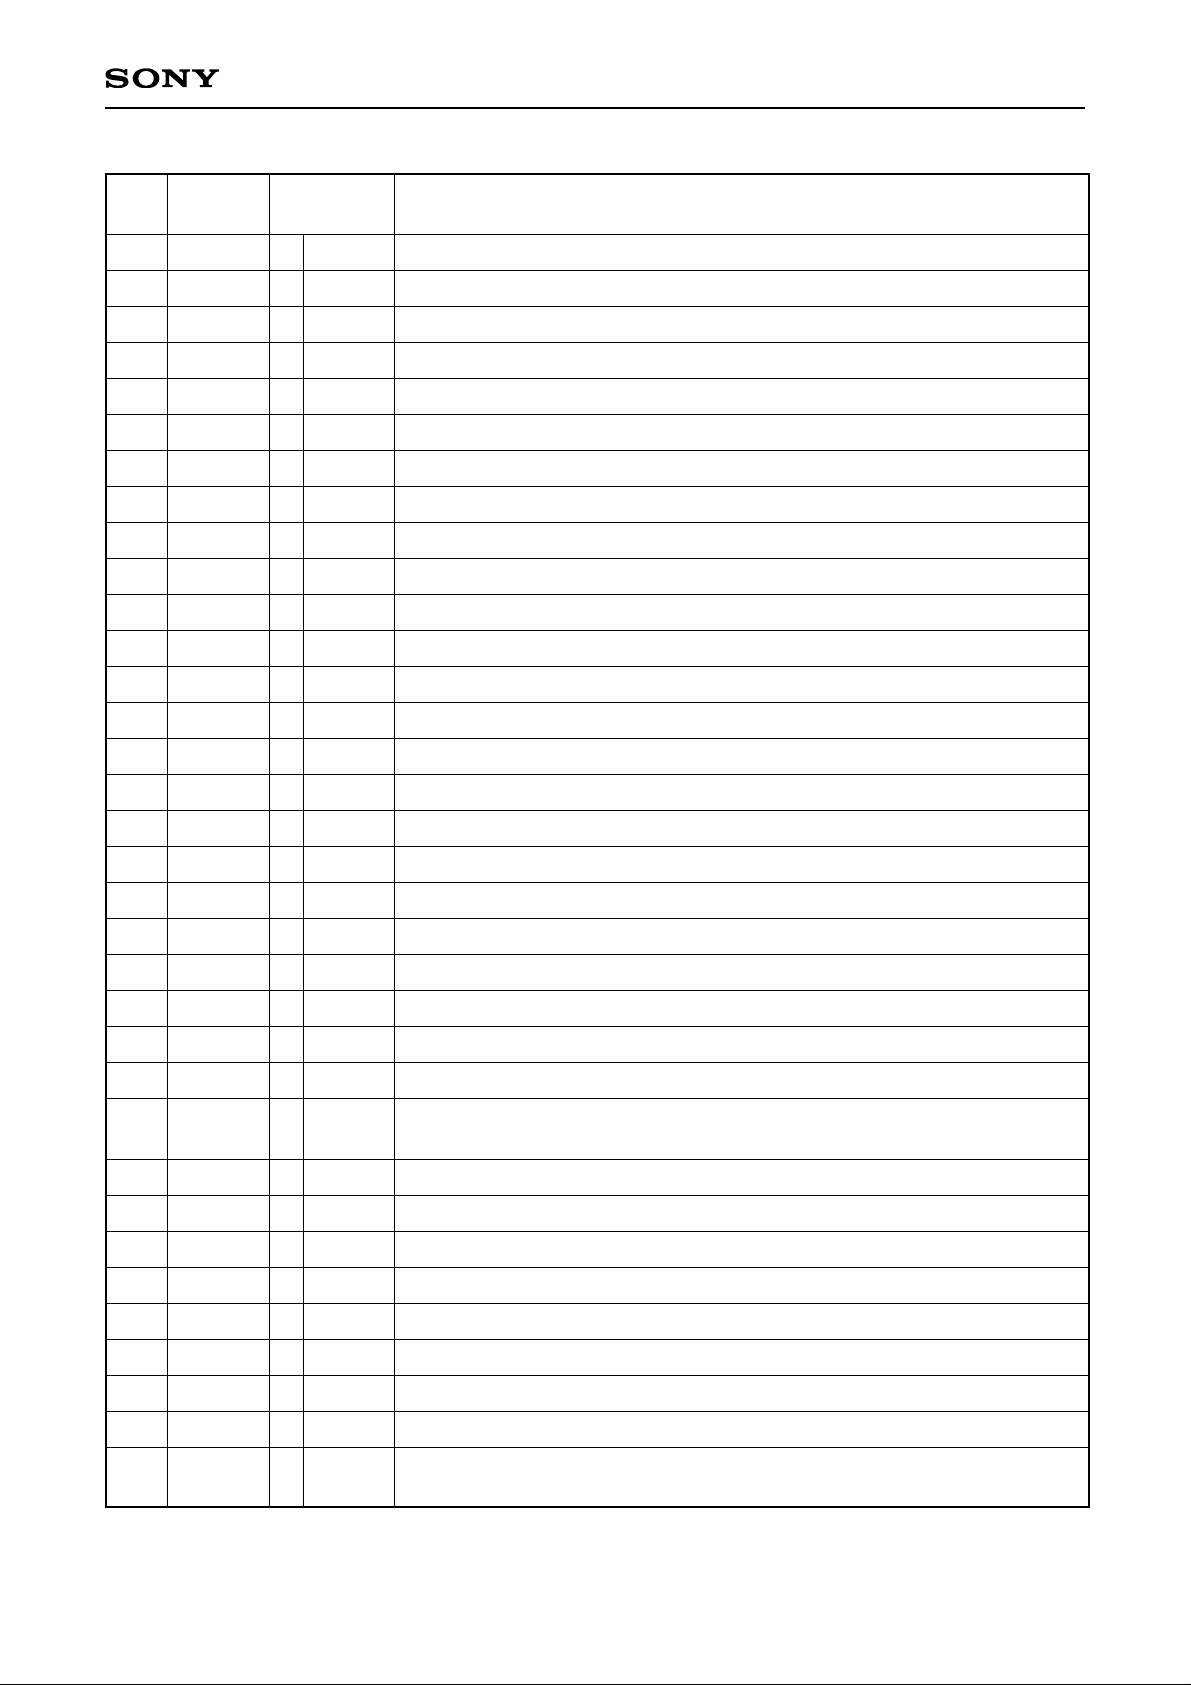
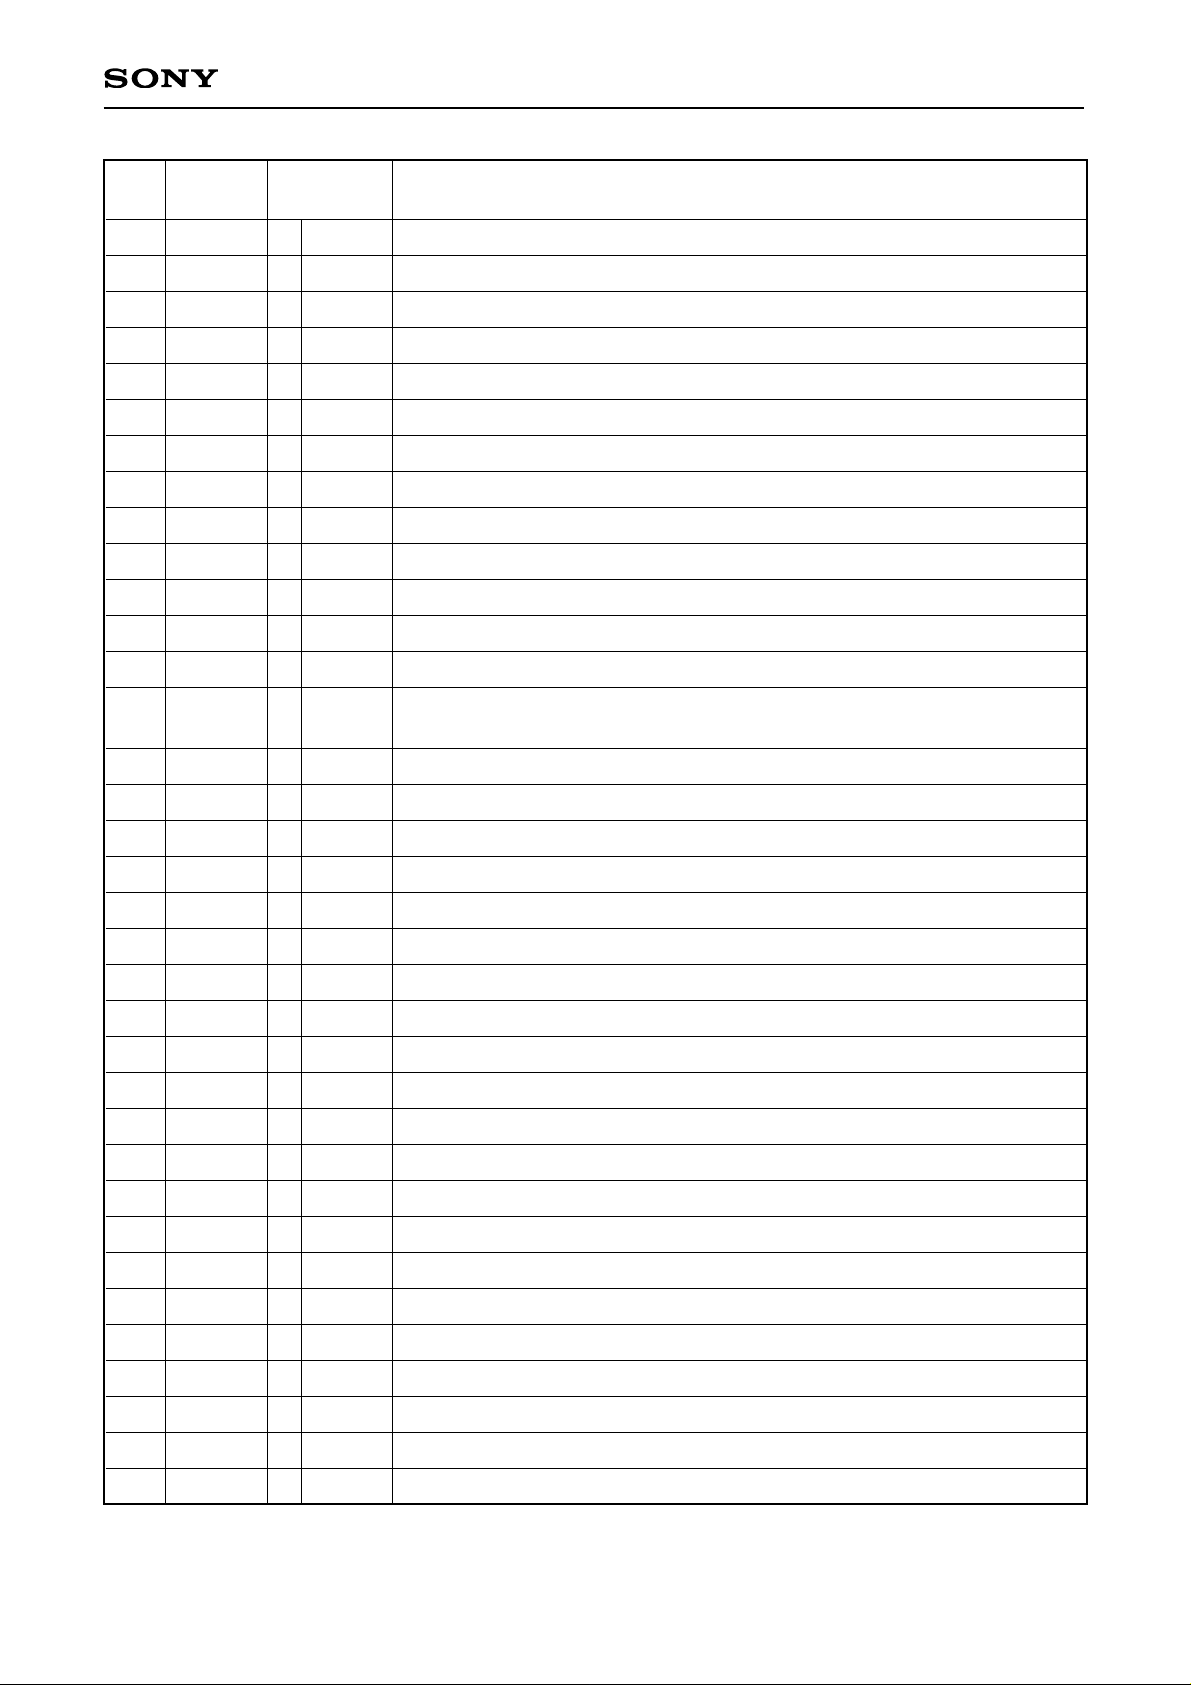
Pin Description
Pin
No.
1
2
3
4
5
6
7
8
9
10
11
12
13
14
15
16
17
18
19
20
21
22
23
24
25
26
27
28
29
30
31
32
33
34
—
—
O
O
O
O
I
I
O
I
I
I
I
I
I
O
I
I/O
O
O
O
O
O
O
O
O
I/O
I/O
—
—
I/O
I/O
I
I/O
—
—
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
—
—
1, 0
1, 0
1, 0
Digital power supply.
Digital GND.
Servo block internal serial data output.
Servo block internal serial data readout clock output.
Servo block internal serial data latch output.
Sub-Q 80-bit, PCM peak and level data outputs. CD TEXT data output.
SQSO readout clock input.
GRSCOR resynchronization input.
Sub P to W serial output.
SBSO readout clock input.
System reset. Reset when low.
Mute input. Muted when high.
Serial data input from CPU.
Latch input from CPU. Serial data is latched at the falling edge.
Serial data transfer clock input from CPU.
SENS output to CPU.
SENS serial data readout clock input.
Anti-shock input/output.
WFCK output.
XUGF output. MNT0 or RFCK is output by switching with the command.
XPCK output. MNT1 is output by switching with the command.
GFS output. MNT2 or XROF is output by switching with the command.
C2PO output. MNT3 or GTOP is output by switching with the command.
Outputs a high signal when either subcode sync S0 or S1 is detected.
4.2336MHz output. In CAV-W mode and variable pitch mode, the 1/4
frequency division of V16M is output.
Word clock output f = 2Fs. GRSCOR is output by switching with the command.
Track count signal input/output.
Mirror signal input/output.
Digital GND.
Digital power supply.
Defect signal input/output.
Focus OK signal input/output.
Spindle motor external control input.
GFS is sampled at 460Hz; when GFS is high, this pin outputs a high signal. If GFS
is low eight consecutive samples, this pin outputs low. Or input when LKIN = 1.
VDD
VSS
SOUT
SOCK
XOLT
SQSO
SQCK
SCSY
SBSO
EXCK
XRST
SYSM
DATA
XLAT
CLOK
SENS
SCLK
ATSK
WFCK
XUGF
XPCK
GFS
C2PO
SCOR
C4M
WDCK
COUT
MIRR
VSS
VDD
DFCT
FOK
PWMI
LOCK
Symbol I/O Description
Page 5
– 5 –
CXD2598Q
35
36
37
38
39
40
41
42
43
44
45
46
47
48
49
50
51
52
53
54
55
56
57
58
59
60
61
62
63
64
65
66
67
68
69
O
I
I/O
O
O
O
O
O
O
—
—
I
I
I
I
I
I
I
I
I
O
—
I
—
O
I
I
—
I
O
I
O
—
I
I
1, Z, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
1, 0
—
—
Analog
—
—
1, 0
—
Analog
1, Z, 0
—
Spindle motor servo control output.
Disc innermost track detection signal input.
Input/output of 2/3 frequency division for the XTAI pin.
Sled drive output.
Sled drive output.
Tracking drive output.
Tracking drive output.
Focus drive output.
Focus drive output.
Digital power supply.
Digital GND.
Test pin. Normally, GND.
Test pin. Normally, GND.
Crystal selection input. Low when the crystal is 16.9344MHz; high when the
crystal is 33.8688MHz.
Center voltage input.
Focus error signal input.
Sled error signal input.
Tracking error signal input.
Center servo analog input.
RF signal input.
Test pin. Do not connect anything.
Analog GND.
Operational amplifier constant current input.
Analog power supply.
EFM full-swing output (low = VSS, high = VDD).
Asymmetry comparator voltage input.
EFM signal input.
Analog GND.
Multiplier VCO1 control voltage input.
Master PLL filter output (slave = digital PLL).
Master PLL filter input.
Master PLL charge pump output.
Analog power supply.
Asymmetry circuit constant current input.
Wide-band EFM PLL VCO2 control voltage input.
MDP
SSTP
FSTIO
SFDR
SRDR
TFDR
TRDR
FFDR
FRDR
VDD
VSS
TEST
TES1
XTSL
VC
FE
SE
TE
CE
RFDC
ADIO
AVSS0
IGEN
AVDD0
ASYO
ASYI
RFAC
AVSS3
CLTV
FILO
FILI
PCO
AVDD3
BIAS
VCTL
Pin
No.
Symbol I/O Description
Page 6
– 6 –
CXD2598Q
70
71
72
73
74
75
76
77
78
79
80
81
82
83
84
85
86
87
88
89
90
91
92
93
94
95
96
97
98
99
100
I/O
O
—
I
O
I
—
O
I
O
I
O
I
O
I
I
O
—
O
I
O
—
—
O
I
O
—
O
O
1, 0
1, Z, 0
—
1, 0
—
1, 0
1, 0
1, 0
1, 0
—
—
—
—
1, 0
1, 0
Wide-band EFM PLL VCO2 oscillation output. Wide-band EFM PLL clock
input by switching with the command.
Wide-band EFM PLL charge pump output.
Digital GND.
Digital Out on/off control (low = off, high = on).
Digital Out output.
Asymmetry circuit on/off (low = off, high = on).
Digital power supply.
D/A interface. LR clock output f = Fs.
D/A interface. LR clock input.
D/A interface. Serial data output. (two's complement, MSB first)
D/A interface. Serial data input. (two's complement, MSB first)
D/A interface. Bit clock output.
D/A interface. Bit clock input.
Outputs a high signal when the playback disc has emphasis, and a low
signal when there is no emphasis.
Inputs a high signal when emphasis is on, and a low signal when emphasis
is off.
Master clock power supply.
Crystal oscillation circuit input. Master clock is externally input from this pin.
Crystal oscillation circuit output.
Master clock GND.
Analog power supply.
Left channel analog output.
Left channel operational amplifier input.
Left channel LINE output.
Analog GND.
Analog GND.
Right channel LINE output.
Right channel operational amplifier input.
Right channel analog output.
Analog power supply.
Right channel zero detection flag.
Left channel zero detection flag.
V16M
VPCO
VSS
MD2
DOUT
ASYE
VDD
LRCK
LRCKI
PCMD
PCMDI
BCK
BCKI
EMPH
EMPHI
XVDD
XTAI
XTAO
XVSS
AVDD1
AOUT1
AIN1
LOUT1
AVSS1
AVSS2
LOUT2
AIN2
AOUT2
AVDD2
RMUT
LMUT
Pin
No.
Symbol I/O Description
Page 7
– 7 –
CXD2598Q
Notes) • PCMD is a MSB first, two's complement output.
• GTOP is used to monitor the frame sync protection status. (High: sync protection window opens.)
• XUGF is the frame sync obtained from the EFM signal, and is negative pulse. It is the signal before
sync protection.
• XPCK is the inverse of the EFM PLL clock. The PLL is designed so that the falling edge and the
EFM signal transition point coincide.
• The GFS signal goes high when the frame sync and the insertion protection timing match.
• RFCK is derived from the crystal accuracy, and has a cycle of 136µs.
• C2PO represents the data error status.
• XRAOF is generated when the 32K RAM exceeds the ±28F jitter margin.
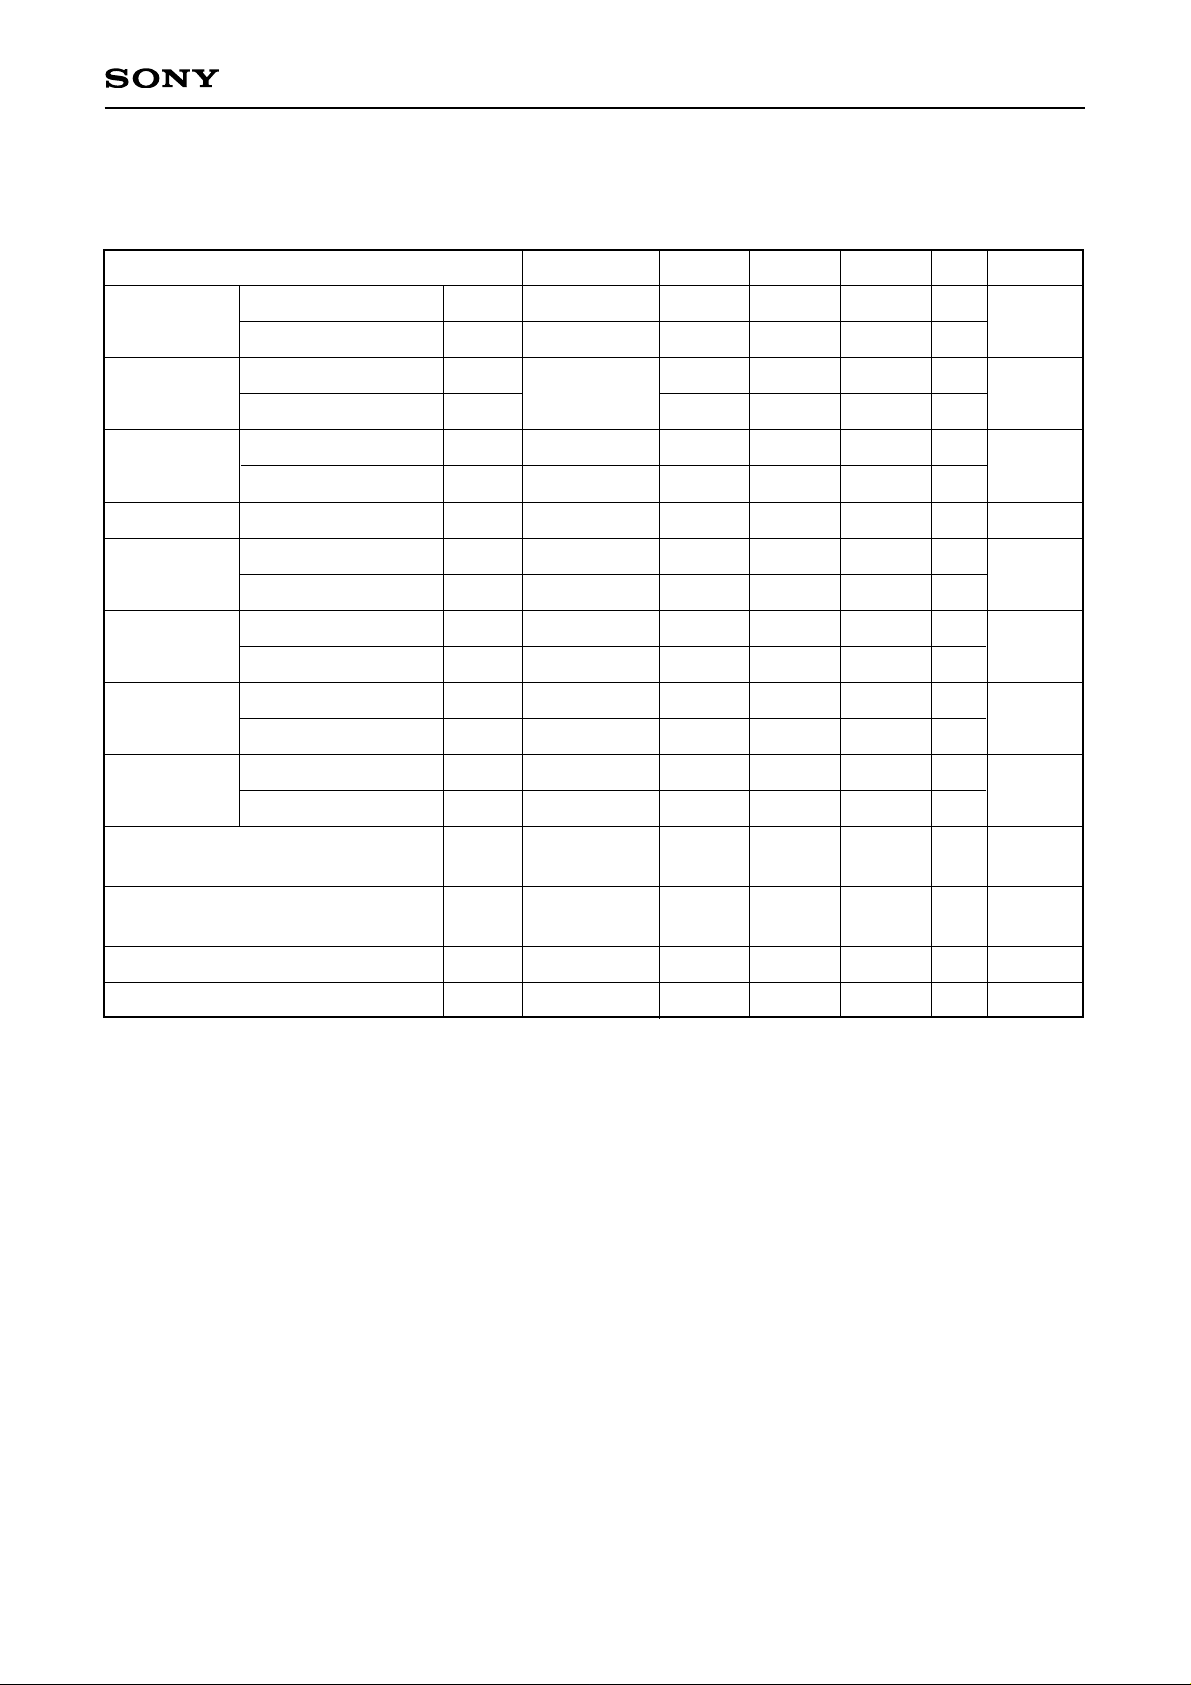
Monitor Pin Output Combinations
Command bit
Output data
MTSL1
MTSL0
XUGF
XPCK
GFS
C2PO
MNT0
MNT1
MNT2
MNT3
RFCK
XPCK
XROF
GTOP
0
0
1
0
1
0
Page 8
– 8 –
CXD2598Q
Electrical Characteristics
1. DC Characteristics (VDD = AVDD = 5.0V ± 5%, VSS = AVSS = 0V, Topr = –20 to +75°C)
Item
Input voltage (1)
Input voltage (2)
Input voltage (3)
Input voltage (4)
Output voltage
(1)
Output voltage
(2)
Output voltage
(3)
Output voltage
(4)
Input leak current (1)
Input leak current (2)
Input leak current (3)
Input leak current (4)
∗1, ∗11
∗2, ∗12
∗3
∗4, ∗9, ∗10
∗5
∗6
∗7
∗1, ∗2
∗3, ∗11, ∗12
∗9
∗10
∗8
Schmitt input
Analog input
IOH = –2mA
IOL = 4mA
IOH = –4mA
IOL = 8mA
IOH = –6mA
IOL = 4mA
IOH = –0.28mA
IOL = 0.36mA
VIN = VSS
or VDD
VIN = VSS
or VDD
VI = 1.5 to 3.5V
VI = 0 to 5.0V
High level input voltage
Low level input voltage
High level input voltage
Low level input voltage
High level input voltage
Low level input voltage
Input voltage
High level output voltage
Low level output voltage
High level output voltage
Low level output voltage
High level output voltage
Low level output voltage
High level output voltage
Low level output voltage
VIH (1)
VIL (1)
VIH (2)
VIL (2)
VIH (3)
VIL (3)
VIN (4)
VOH (1)
VOL (1)
VOH (2)
VOL (2)
VOH (3)
VOL (3)
VOH (4)
VOL (4)
ILI (1)
ILI (2)
ILI (3)
ILI (4)
0.7VDD
0.8VDD
0.8VDD
Vss
VDD – 0.8
Vss
VDD – 0.8
Vss
VDD – 0.8
Vss
VDD – 0.5
Vss
–10
–40
–20
–40
0.3VDD
0.2VDD
0.2VDD
VDD
VDD
0.4
VDD
0.4
VDD
0.4
VDD
0.4
10
40
20
600
V
V
V
V
V
V
V
V
V
V
V
V
V
V
V
µA
µA
µA
µA
Conditions Min. Typ. Max. Unit
Applicable pins
Applicable pins
∗1
SYSM, DATA, XLAT, PWMI, SSTP, XTSL, TEST, TES1, MD2, SCSY
∗2
SQCK, XRST, CLOK, ASYE
∗3
LRCKI, PCMDI, BCKI, EMPHI
∗4
ASYI, RFAC, CLTV, FILI, VCTL
∗5
SQSO, SBSO, SENS, ATSK, WFCK, XUGF, XPCK, GFS, C2PO, SCOR, C4M, WDCK, COUT, MIRR,
DFCT, FOK, LOCK, FSTIO, SFDR, SRDR, TFDR, TRDR, FFDR, FRDR, ASYO, DOUT, LRCK, PCMD,
BCK, EMPH, RMUT, LMUT, SOUT, SOCK, XOLT
∗6
V16M
∗7
MDP, PCO, VPCO
∗8
FILO
∗9
VC, FE, SE, TE, CE
∗10
RFDC
∗11
EXCK, ATSK, COUT, MIRR, DFCT, FOK, LOCK, PWMI, V16M, FSTIO
∗12
SCLK
Page 9

– 9 –
CXD2598Q
2. AC Characteristics
(1) XTAI pin
(a) When using self-excited oscillation
(Topr = –20 to +75°C, VDD = AVDD = 5.0V ± 5%)
(b) When inputting pulses to XTAI pin
(Topr = –20 to +75°C, VDD = AVDD = 5.0V ± 5%)
(c) When inputting sine waves to XTAI pin via a capacitor
(Topr = –20 to +75°C, VDD = AVDD = 5.0V ± 5%)
Oscillation frequency fMAX 7 34 MHz
Item Symbol Min. Typ. Max. Unit
High level pulse width
Low level pulse width
Pulse cycle
Input high level
Input low level
Rise time, fall time
tWHX
13
500
ns
tWLX
13 500
ns
tCX
26 1000
ns
VIHX
VDD – 1.0
V
VILX 0.8
V
tR, tF
10
ns
Item Symbol Min. Typ. Max. Unit
Input amplitude VI 2.0 VDD + 0.3 Vp-p
Item Symbol Min. Typ. Max. Unit
tR tF
tWHX
tWLX
tCX
VILX
VIHX × 0.1
V
IHX × 0.9
V
IHX
XTAI
V
DD/2
Page 10

– 10 –
CXD2598Q
(2) CLOK, DATA, XLAT, SQCK and EXCK pins
(VDD = AVDD = 5.0V ± 5%, VSS = AVSS = 0V, Topr = –20 to +75°C)
Clock frequency
Clock pulse width
Setup time
Hold time
Delay time
Latch pulse width
EXCK SQCK frequency
EXCK SQCK pulse width
COUT frequency (during input)
∗
COUT pulse width (during input)
∗
fCK
tWCK
tSU
tH
tD
tWL
fT
tWT
fT
tWT
750
300
300
300
750
750
7.5
0.65
0.65
65
MHz
ns
ns
ns
ns
ns
MHz
ns
kHz
µs
Item Symbol Min. Typ. Max. Unit
tWCK tWCK
1/fCK
tH
tSU
tWL
tD
1/fT
tWT tWT
tH
tSU
CLOK
DATA
XLAT
EXCK
SQCK
COUT
SBSO
SQSO
∗
Only when $44 and $45 are executed.
Page 11

– 11 –
CXD2598Q
(3) BCKI, LRCKI and PCMDI pins
(VDD = AVDD = 5.0V ± 5%, VSS = AVSS = 0V, Topr = –20 to +75°C)
BCK pulse width
PCMDI setup time
PCMDI hold time
LRCK setup time
tW
tSU
tH
tSU
ns
ns
ns
ns
Item Symbol
Conditions
Typ.
94
18
18
18
Min.
Max. Unit
VDD/2 VDD/2
tW(BCKI) tW(BCKI)
tSU
(PCMDI)
t
H
(PCMDI)
tSU
(LRCKI)
BCKI
PCMDI
LRCKI
(4) SCLK pin
SCLK frequency
SCLK pulse width
Delay time
fSCLK
tSPW
tDLS
31.3
15
16 MHz
ns
µs
Item Symbol Min. Typ. Max. Unit
tSPWtDLS
1/fSCLK
MSB LSB· · ·
· · ·
XLAT
SCLK
Serial Read Out Data
(SENS)
Page 12
– 12 –
CXD2598Q
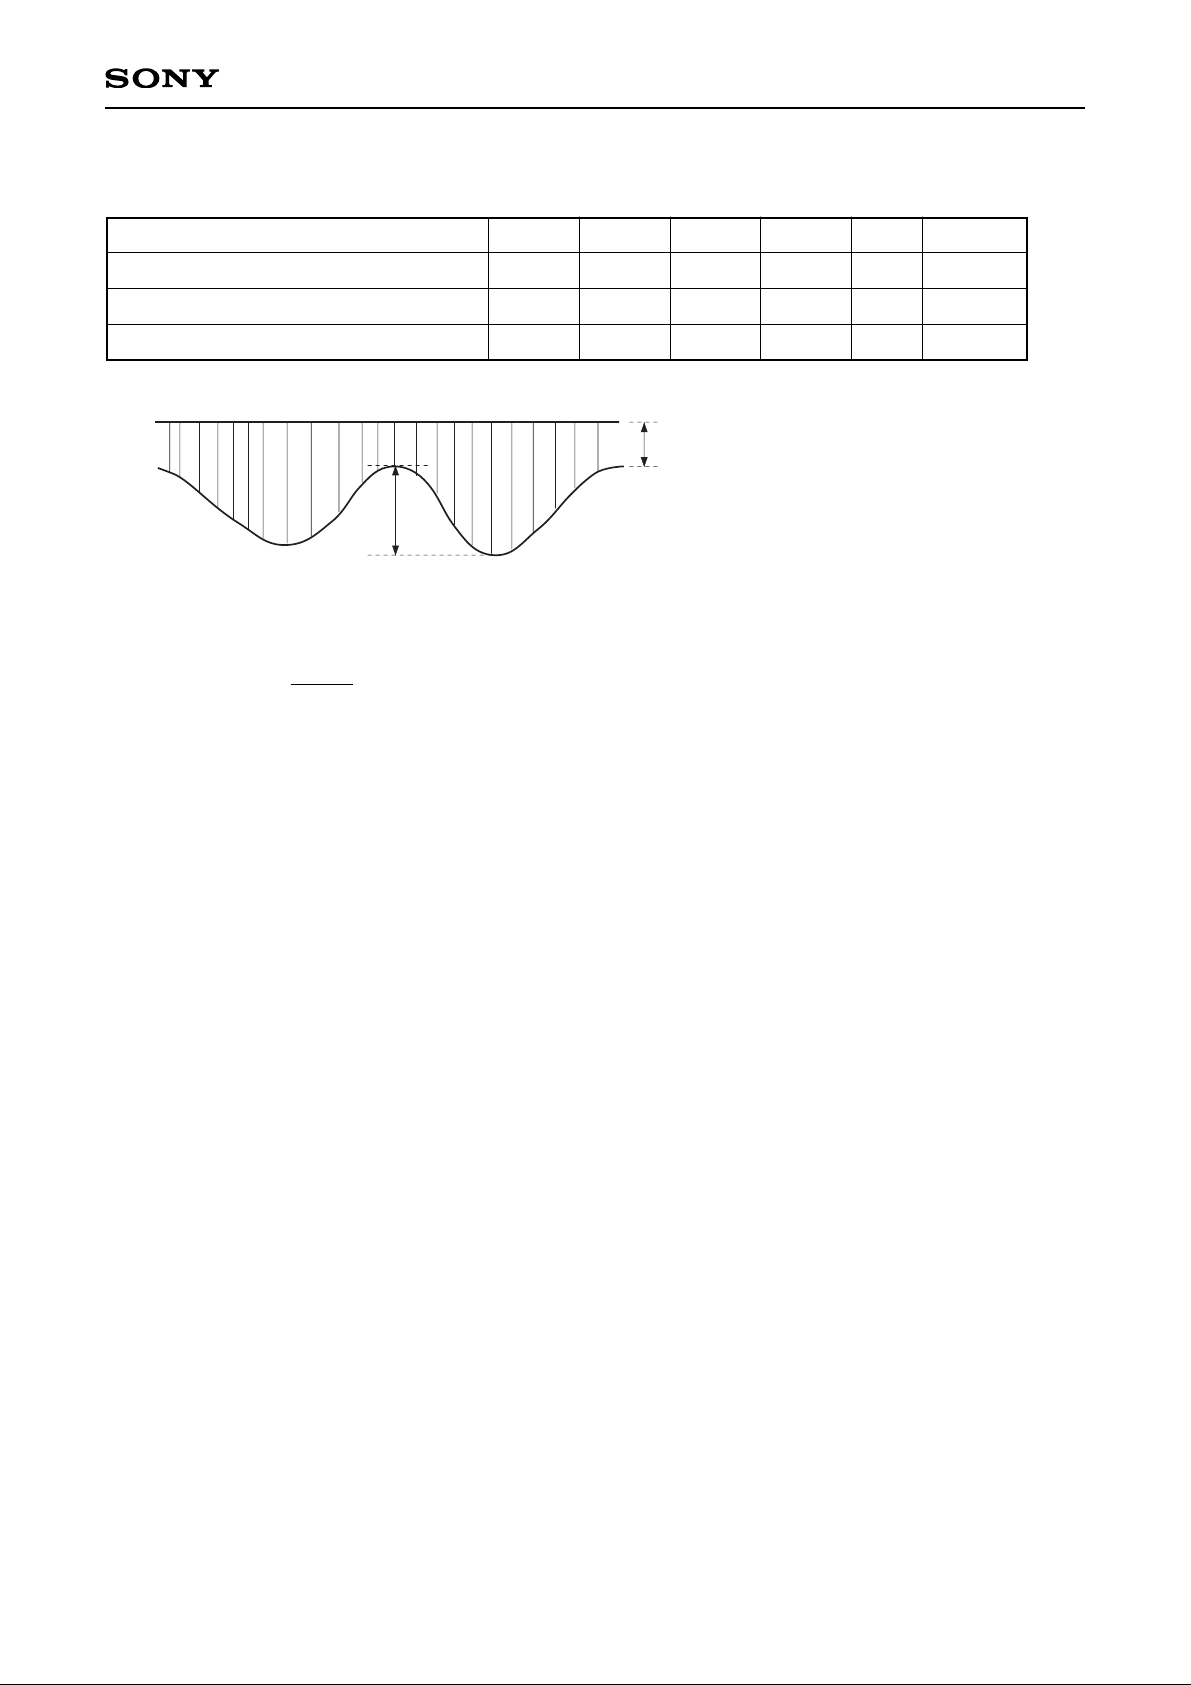
(5) COUT, MIRR and DFCT pins
Operating frequency (VDD = AVDD = 5.0V ± 5%, VSS = AVSS = 0V, Topr = –20 to +75°C)
COUT maximum operating frequency
MIRR maximum operating frequency
DFCT maximum operating frequency
fCOUT
fMIRR
fDFCTH
40
40
5
kHz
kHz
kHz
∗1
∗2
∗3
Item Symbol Min. Typ. Max. Max.
Conditions
∗1
When using a high-speed traverse TZC.
∗2
When the RF signal continuously satisfies the following conditions during the above traverse.
• A = 0.12VDD to 0.26VDD
• ≤ 25%
∗3
During complete RF signal omission.
When settings related to DFCT signal generation are Typ.
A
B
B
A + B
Page 13

– 13 –
CXD2598Q
1-bit DAC and LPF Block Analog Characteristics
Analog characteristics (VDD = AVDD = 5.0V, VSS = AVSS = 0V, Ta = 25°C)
Item
Total harmonic
distortion
Signal-to-noise ratio
Symbol
THD
S/N
Conditions
1kHz, 0dB data
Crystal
1kHz, 0dB data
(Using A-weighting filter)
384Fs
768Fs
384Fs
768Fs
96
96
0.0050
0.0045
100
100
0.0070
0.0065
Min.
Typ.
Max.
Unit
%
dB
Audio Analyzer
SHIBASOKU (AM51A)
100k
22µ
680p
12k
12k
12k
150p
AOUT1 (2)
AIN1 (2)
LOUT1 (2)
Audio Analyzer
CXD2598Q
Rch A
Lch B
DATA RF
TEST DISC
768Fs/384Fs
(VDD = AVDD = 5.0V, VSS = AVSS = 0V, Topr = –20 to +75°C)
Output voltage
Load resistance
VOUT
RL
∗1
∗1
Vrms
kΩ
Item Symbol
8
Min.
Max.
1.12
Typ.
Applicable pinsUnit
∗
Measurement is conducted for the above circuit diagrams with the sine wave output of 1kHz and 0dB.
Applicable pins
∗1
LOUT1, LOUT2
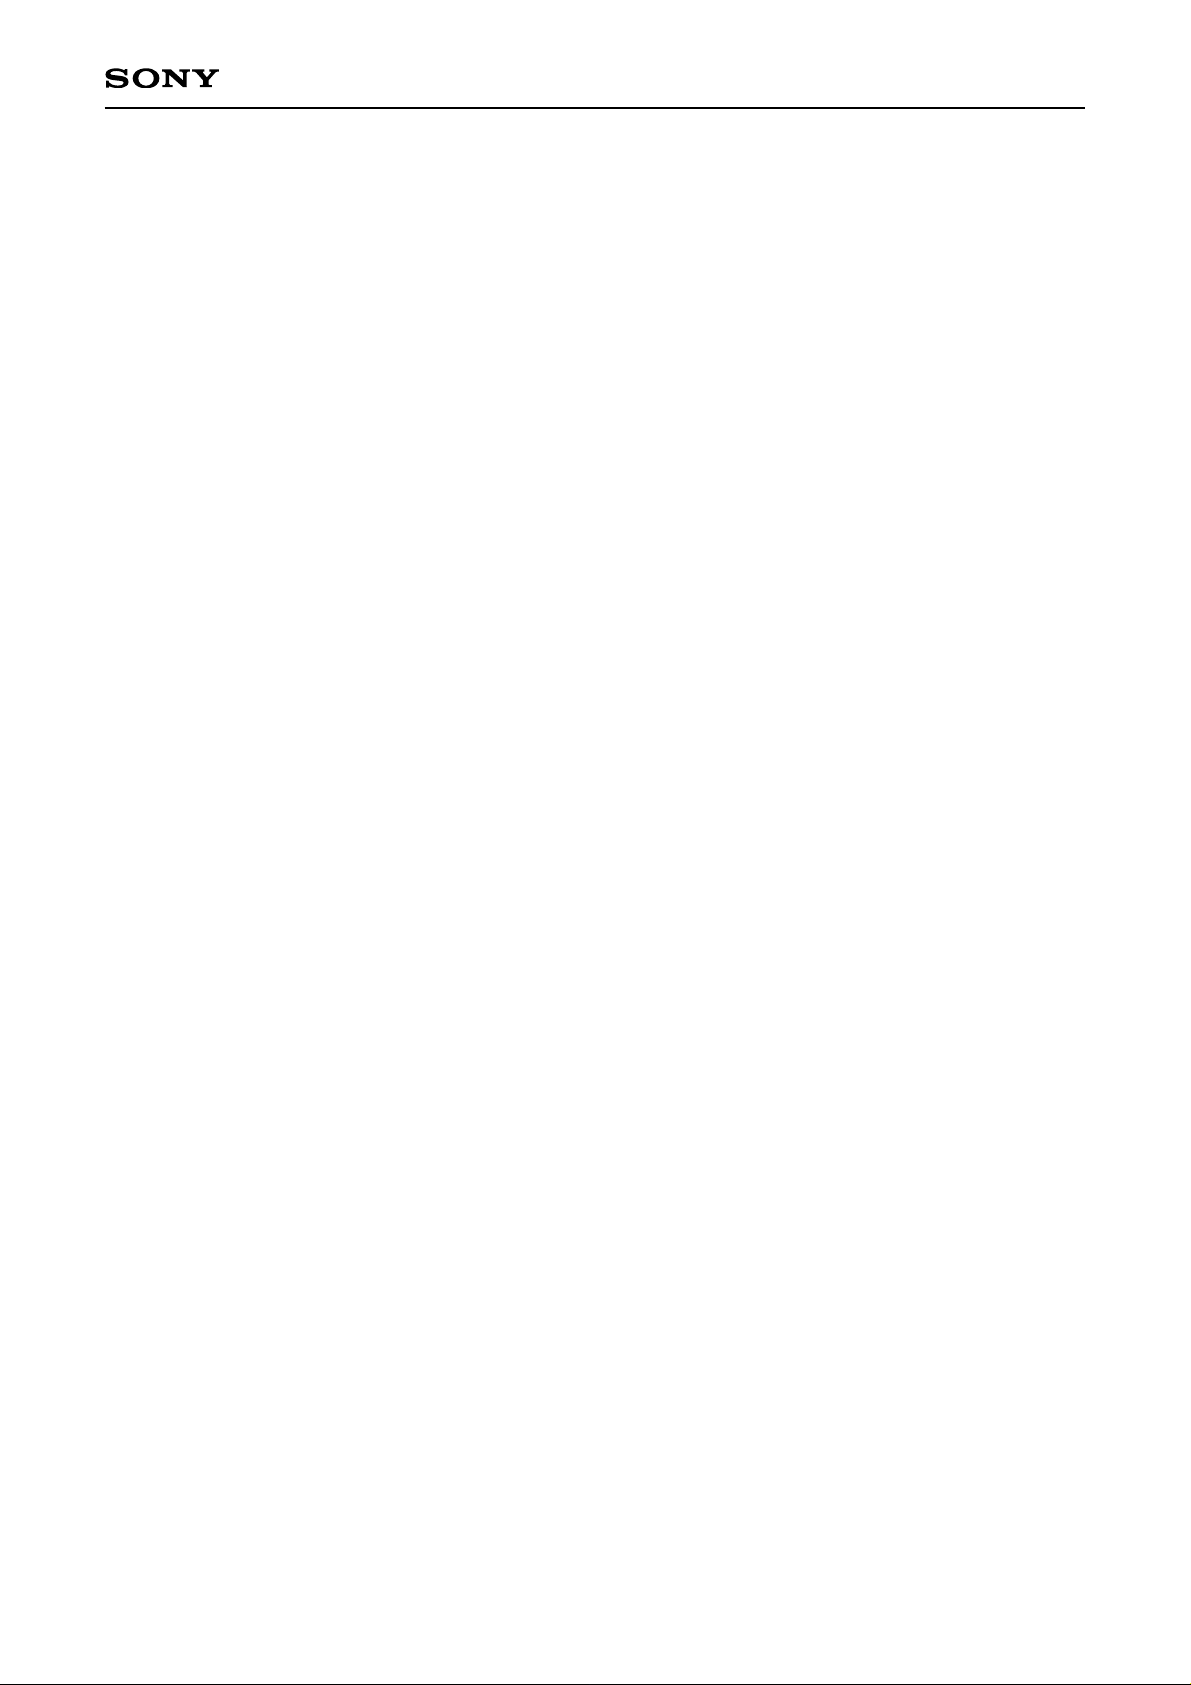
Block diagram of analog characteristics measurement
LPF external circuit diagram
Fs = 44.1kHz in all cases.
The total harmonic distortion and signal-to-noise ratio measurement circuits are shown below.
Page 14
– 14 –
CXD2598Q
Contents
§1. CPU Interface
§1-1. CPU Interface Timing ..........................................................................................................................15
§1-2. CPU Interface Command Table ..........................................................................................................15
§1-3. CPU Command Presets ......................................................................................................................26
§1-4. Description of SENS Signals...............................................................................................................32
§1-5. Description of Commands ...................................................................................................................34
§2. Subcode Interface
§2-1. P to W Subcode Readout....................................................................................................................62
§2-2. 80-bit Sub-Q Readout..........................................................................................................................62
§3. Description of Modes
§3-1. CLV-N Mode........................................................................................................................................69
§3-2. CLV-W Mode.......................................................................................................................................69
§3-3. CAV-W Mode.......................................................................................................................................69
§3-4. VCO-C mode.......................................................................................................................................70
§4. Description of Other Functions
§4-1. Channel Clock Recovery by Digital PLL Circuit...................................................................................73
§4-2. Frame Sync Protection........................................................................................................................75
§4-3. Error Correction...................................................................................................................................75
§4-4. DA Interface.........................................................................................................................................76
§4-5. Digital Out............................................................................................................................................78
§4-6. Servo Auto Sequence..........................................................................................................................82
§4-7. Digital CLV...........................................................................................................................................90
§4-8. CD-DSP Block Playback Speed..........................................................................................................91
§4-9. DAC Block Playback Speed ................................................................................................................91
§4-10. DAC Block Input Timing ....................................................................................................................92
§4-11. Description of DAC Block Functions..................................................................................................92
§4-12. LPF Block ..........................................................................................................................................97
§4-13. Asymmetry Correction.......................................................................................................................98
§4-14. CD TEXT Data Demodulation ...........................................................................................................99
§5. Description of Servo Signal Processing System Functions and Commands
§5-1. General Description of Servo Signal Processing System..................................................................101
§5-2. Digital Servo Block Master Clock (MCK)...........................................................................................102
§5-3. DC Offset Cancel [AVRG Measurement and Compensation] ...........................................................103
§5-4. E:F Balance Adjustment Function .....................................................................................................104
§5-5. FCS Bias Adjustment Function..........................................................................................................104
§5-6. AGCNTL Function .............................................................................................................................106
§5-7. FCS Servo and FCS Search .............................................................................................................108
§5-8. TRK and SLD Servo Control .............................................................................................................109
§5-9. MIRR and DFCT Signal Generation..................................................................................................110
§5-10. DFCT Countermeasure Circuit........................................................................................................111
§5-11. Anti-Shock Circuit............................................................................................................................111
§5-12. Brake Circuit....................................................................................................................................112
§5-13. COUT Signal ...................................................................................................................................113
§5-14. Serial Readout Circuit......................................................................................................................113
§5-15. Writing to Coefficient RAM ..............................................................................................................114
§5-16. PWM Output....................................................................................................................................114
§5-17. Servo Status Changes Produced by LOCK Signal ........................................................................115
§5-18. Description of Commands and Data Sets .......................................................................................115
§5-19. List of Servo Filter Coefficients........................................................................................................137
§5-20. Filter Composition............................................................................................................................139
§5-21. TRACKING and FOCUS Frequency Response ..............................................................................145
§6. Application Circuit...................................................................................................................................146
Explanation of abbreviations
AVRG: Average TRK: Tracking
AGCNTL: Auto gain control SLD: Sled
FCS: Focus DFCT: Defect
Page 15
– 15 –
CXD2598Q
§1. CPU Interface
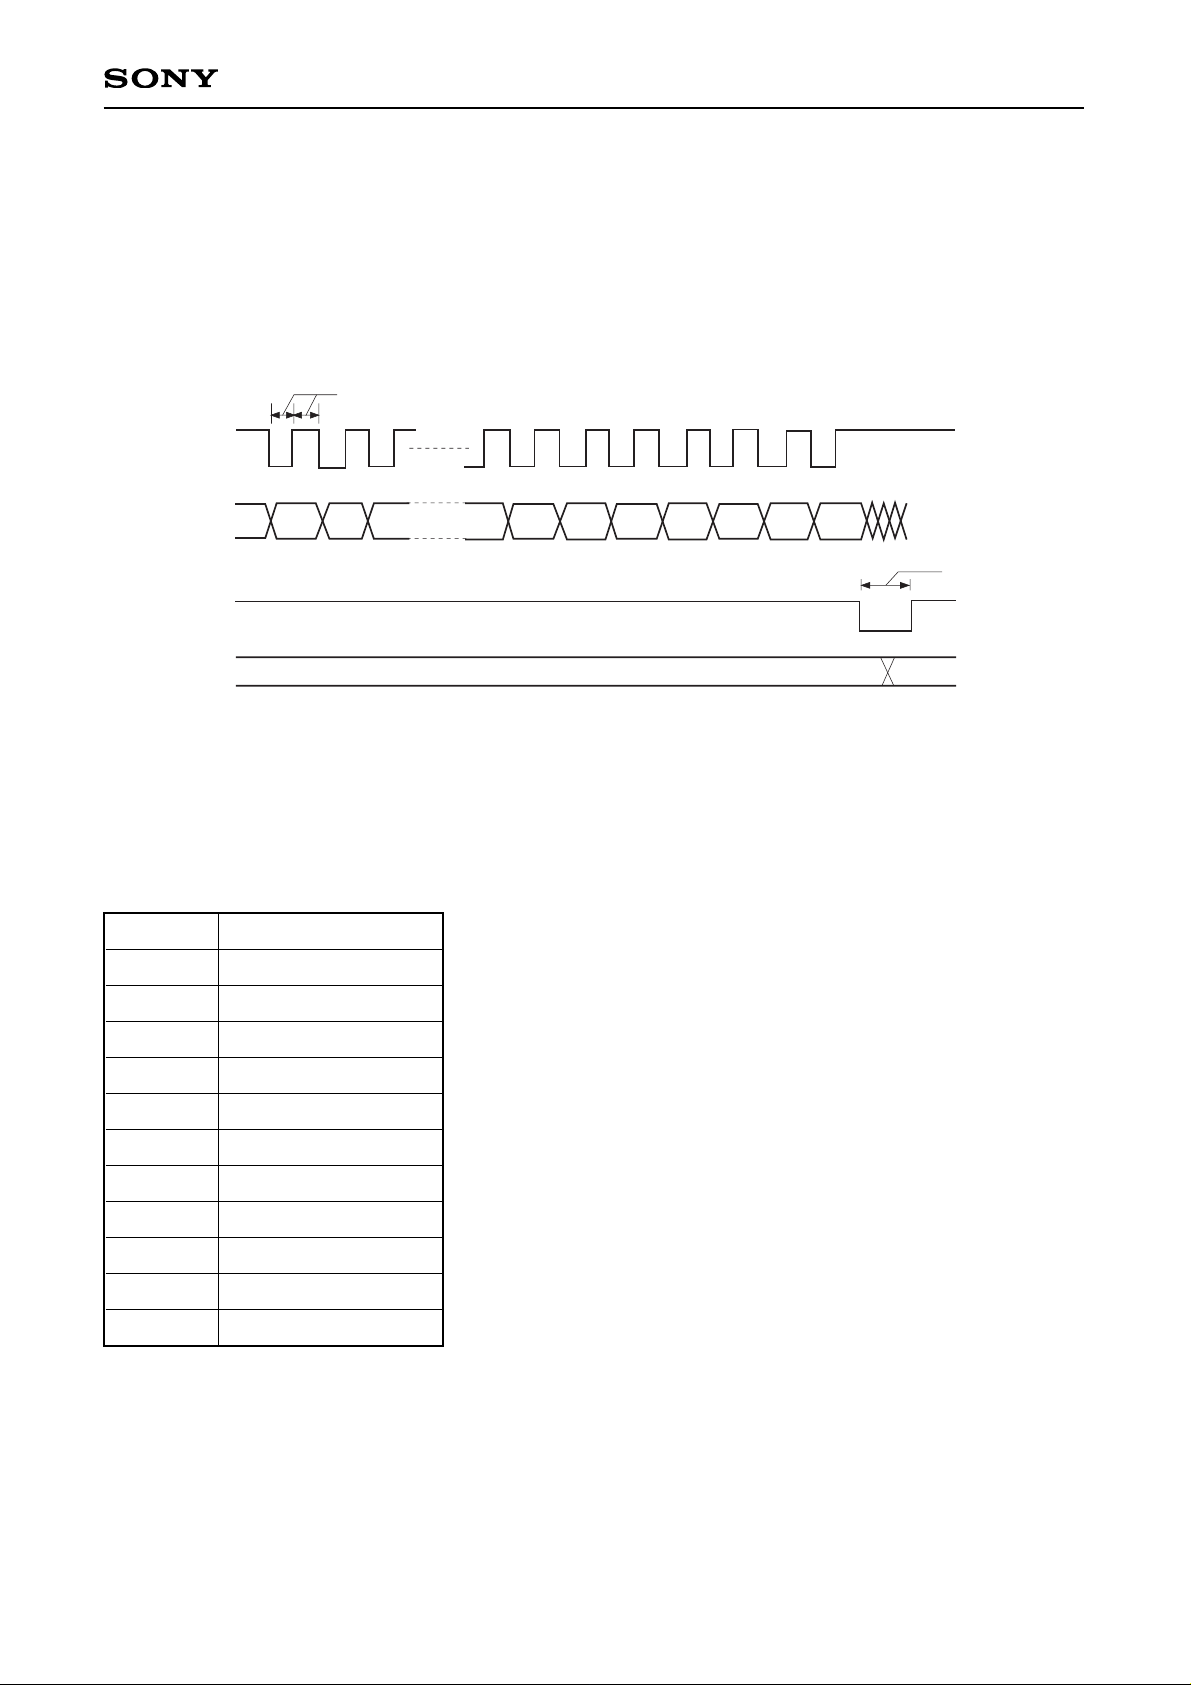
§1-1. CPU Interface Timing
• CPU interface
This interface uses DATA, CLOK and XLAT to set the modes.
The interface timing chart is shown below.
• The internal registers are initialized by a reset when XRST = 0.
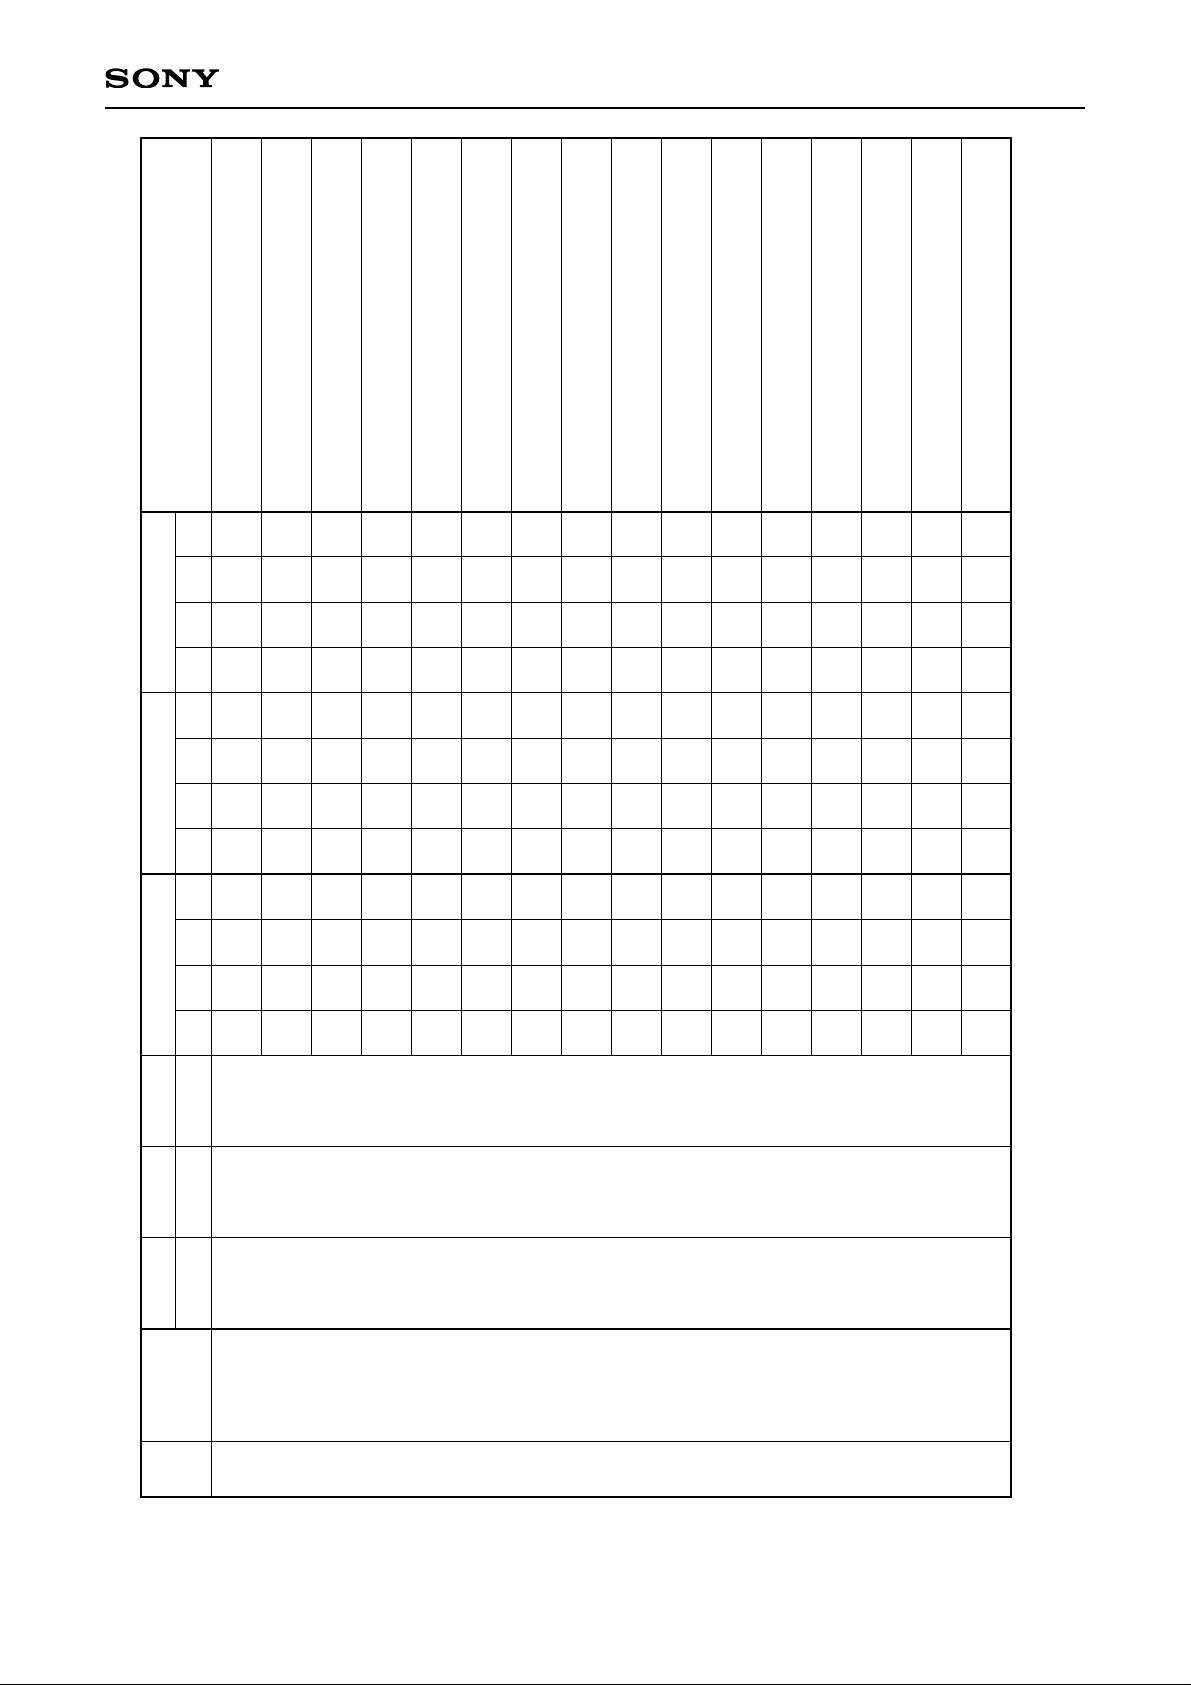
§1-2. CPU Interface Command Table
Total bit length for each register
Register
0 to 2
3
4 to 6
7
8
9
A
B
C
D
E
8 bits
8 to 24 bits
16 bits
20 bits
32 bits
32 bits
28 bits
24 bits
28 bits
20 bits
20 bits
Total bit length
750ns or more
D18 D19 D20 D21 D22 D23
750ns or more
Valid
CLOK
DATA
XLAT
Registers
D0 D1
Page 16

– 16 –
CXD2598Q
FOCUS SERVO ON
(FOCUS GAIN
NORMAL)
FOCUS SERVO ON
(FOCUS GAIN
DOWN)
FOCUS SERVO OFF,
0V OUT
FOCUS SERVO OFF,
FOCUS SEARCH
VOLTAGE OUT
FOCUS SEARCH
VOLTAGE DOWN
FOCUS SEACH
VOLTAGE UP
ANTI SHOCK ON
ANTI SHOCK OFF
BRAKE ON
BRAKE OFF
TRACKING GAIN
NORMAL
TRACKING GAIN UP
TRACKING GAIN UP
FILTER SELECT 1
TRACKING GAIN UP
FILTER SELECT 2
1
1
0
0
0
0
1
0
—
—
—
—
—
—
0
1
—
—
—
—
0
—
1
0
—
—
—
—
—
—
0
1
1
1
—
—
—
—
0
1
—
—
—
—
—
—
0
1
—
—
—
—
—
—
1
0
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
0
1
0 0 0 0
0 0 0 1
FOCUS
CONTROL
TRACKING
CONTROL
Register
Command
Address
D23 to D20
Data 1
D19 D18 D17 D16
Data 2
D15 D14 D13 D12
Data 3
D11 D10 D9 D8
Data 4
D7 D6 D5 D4
Data 5
D3 D2 D1 D0
Command Table ($0X to 1X)
—: Don’t care
Page 17

– 17 –
CXD2598Q
TRACKING SERVO OFF
TRACKING SERVO ON
FORWARD TRACK JUMP
REVERSE TRACK JUMP
SLED SERVO OFF
SLED SERVO ON
FORWARD SLED MOVE
REVERSE SLED MOVE
SLED KICK LEVEL
(±1 × basic value) (Default)
SLED KICK LEVEL
(±2 × basic value)
SLED KICK LEVEL
(±3 × basic value)
SLED KICK LEVEL
(±4 × basic value)
0
0
1
1
—
—
—
—
0
0
0
0
0
0
0
0
0
0
1
1
0
1
0
1
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
0
1
0
1
—
—
—
—
—
—
—
—
0
0
1
1
—
—
—
—
0
1
0
1
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
2
3
0 0 1 0
0 0 1 1
TRACKING
MODE
SELECT
Register
Command
Address
D23 to D20
Register
Command
Address
D23 to D20
Data 1
D19 D18 D17 D16
Data 1
D19 D18 D17 D16
Data 2
D15 D14 D13 D12
Data 2
D15 D14 D13 D12
Data 3
D11 D10 D9 D8
Data 4
D7 D6 D5 D4
Data 5
D3 D2 D1 D0
Data 3
D11 D10 D9 D8
Data 4
D7 D6 D5 D4
Data 5
D3 D2 D1 D0
—: Don’t care
Command Table ($2X to 3X)
Page 18
– 18 –
CXD2598Q
KRAM DATA (K00)
SLED INPUT GAIN
KRAM DATA (K01)
SLED LOW BOOST FILTER A-H
KRAM DATA (K02)
SLED LOW BOOST FILTER A-L
KRAM DATA (K03)
SLED LOW BOOST FILTER B-H
KRAM DATA (K04)
SLED LOW BOOST FILTER B-L
KRAM DATA (K05)
SLED OUTPUT GAIN
KRAM DATA (K06)
FOCUS INPUT GAIN
KRAM DATA (K07)
SLED AUTO GAIN
KRAM DATA (K08)
FOCUS HIGH CUT FILTER A
KRAM DATA (K09)
FOCUS HIGH CUT FILTER B
KRAM DATA (K0A)
FOCUS LOW BOOST FILTER A-H
KRAM DATA (K0B)
FOCUS LOW BOOST FILTER A-L
KRAM DATA (K0C)
FOCUS LOW BOOST FILTER B-H
KRAM DATA (K0D)
FOCUS LOW BOOST FILTER B-L
KRAM DATA (K0E)
FOCUS PHASE COMPENSATE FILTER A
KRAM DATA (K0F)
FOCUS DEFECT HOLD GAIN
0
0
0
0
0
0
0
0
1
1
1
1
1
1
1
1
0
0
0
0
1
1
1
1
0
0
0
0
1
1
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
3 0 0 1 1 0 1 0 0 0 0 0 0SELECT
Register
Command
Address 1
D23 to D20
Address 2
D19 to D16
Address 3
D15 to D12
Address 4
D11 D10 D9 D8
Data 1
D7 D6 D5 D4
Data 2
D3 D2 D1 D0
Command Table ($340X)
Page 19

– 19 –
CXD2598Q
KRAM DATA (K10)
FOCUS PHASE COMPENSATE FILTER B
KRAM DATA (K11)
FOCUS OUTPUT GAIN
KRAM DATA (K12)
ANTI SHOCK INPUT GAIN
KRAM DATA (K13)
FOCUS AUTO GAIN
KRAM DATA (K14)
HPTZC / AUTO GAIN HIGH PASS FILTER A
KRAM DATA (K15)
HPTZC / AUTO GAIN HIGH PASS FILTER B
KRAM DATA (K16)
ANTI SHOCK HIGH PASS FILTER A
KRAM DATA (K17)
HPTZC / AUTO GAIN LOW PASS FILTER B
KRAM DATA (K18)
FIX
KRAM DATA (K19)
TRACKING INPUT GAIN
KRAM DATA (K1A)
TRACKING HIGH CUT FILTER A
KRAM DATA (K1B)
TRACKING HIGH CUT FILTER B
KRAM DATA (K1C)
TRACKING LOW BOOST FILTER A-H
KRAM DATA (K1D)
TRACKING LOW BOOST FILTER A-L
KRAM DATA (K1E)
TRACKING LOW BOOST FILTER B-H
KRAM DATA (K1F)
TRACKING LOW BOOST FILTER B-L
0
0
0
0
0
0
0
0
1
1
1
1
1
1
1
1
0
0
0
0
1
1
1
1
0
0
0
0
1
1
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
3 0 0 1 1 0 1 0 0 0 0 0 1SELECT
Register
Command
Address 1
D23 to D20
Address 2
D19 to D16
Address 3
D15 to D12
Address 4
D11 D10 D9 D8
Data 1
D7 D6 D5 D4
Data 2
D3 D2 D1 D0
Command Table ($341X)
Page 20

– 20 –
CXD2598Q
KRAM DATA (K20)
TRACKING PHASE COMPENSATE FILTER A
KRAM DATA (K21)
TRACKING PHASE COMPENSATE FILTER B
KRAM DATA (K22)
TRACKING OUTPUT GAIN
KRAM DATA (K23)
TRACKING AUTO GAIN
KRAM DATA (K24)
FOCUS GAIN DOWN HIGH CUT FILTER A
KRAM DATA (K25)
FOCUS GAIN DOWN HIGH CUT FILTER B
KRAM DATA (K26)
FOCUS GAIN DOWN LOW BOOST FILTER A-H
KRAM DATA (K27)
FOCUS GAIN DOWN LOW BOOST FILTER A-L
KRAM DATA (K28)
FOCUS GAIN DOWN LOW BOOST FILTER B-H
KRAM DATA (K29)
FOCUS GAIN DOWN LOW BOOST FILTER B-L
KRAM DATA (K2A)
FOCUS GAIN DOWN PHASE COMPENSATE FILTER A
KRAM DATA (K2B)
FOCUS GAIN DOWN DEFECT HOLD GAIN
KRAM DATA (K2C)
FOCUS GAIN DOWN PHASE COMPENSATE FILTER B
KRAM DATA (K2D)
FOCUS GAIN DOWN OUTPUT GAIN
KRAM DATA (K2E)
NOT USED
KRAM DATA (K2F)
NOT USED
0
0
0
0
0
0
0
0
1
1
1
1
1
1
1
1
0
0
0
0
1
1
1
1
0
0
0
0
1
1
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
3 0 0 1 1 0 1 0 0 0 0 1 0SELECT
Register
Command
Address 1
D23 to D20
Address 2
D19 to D16
Address 3
D15 to D12
Address 4
D11 D10 D9 D8
Data 1
D7 D6 D5 D4
Data 2
D3 D2 D1 D0
Command Table ($342X)
Page 21

– 21 –
CXD2598Q
KRAM DATA (K30)
SLED INPUT GAIN (when SFSK = 1 TGup2)
KRAM DATA (K31)
ANTI SHOCK LOW PASS FILTER B
KRAM DATA (K32)
NOT USED
KRAM DATA (K33)
ANTI SHOCK HIGH PASS FILTER B-H
KRAM DATA (K34)
ANTI SHOCK HIGH PASS FILTER B-L
KRAM DATA (K35)
ANTI SHOCK FILTER COMPARATE GAIN
KRAM DATA (K36)
TRACKING GAIN UP2 HIGH CUT FILTER A
KRAM DATA (K37)
TRACKING GAIN UP2 HIGH CUT FILTER B
KRAM DATA (K38)
TRACKING GAIN UP2 LOW BOOST FILTER A-H
KRAM DATA (K39)
TRACKING GAIN UP2 LOW BOOST FILTER A-L
KRAM DATA (K3A)
TRACKING GAIN UP2 LOW BOOST FILTER B-H
KRAM DATA (K3B)
TRACKING GAIN UP2 LOW BOOST FILTER B-L
KRAM DATA (K3C)
TRACKING GAIN UP PHASE COMPENSATE FILTER A
KRAM DATA (K3D)
TRACKING GAIN UP PHASE COMPENSATE FILTER B
KRAM DATA (K3E)
TRACKING GAIN UP OUTPUT GAIN
KRAM DATA (K3F)
NOT USED
0
0
0
0
0
0
0
0
1
1
1
1
1
1
1
1
0
0
0
0
1
1
1
1
0
0
0
0
1
1
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
3 0 0 1 1 0 1 0 0 0 0 1 1SELECT
Register
Command
Address 1
D23 to D20
Address 2
D19 to D16
Address 3
D15 to D12
Address 4
D11 D10 D9 D8
Data 1
D7 D6 D5 D4
Data 2
D3 D2 D1 D0
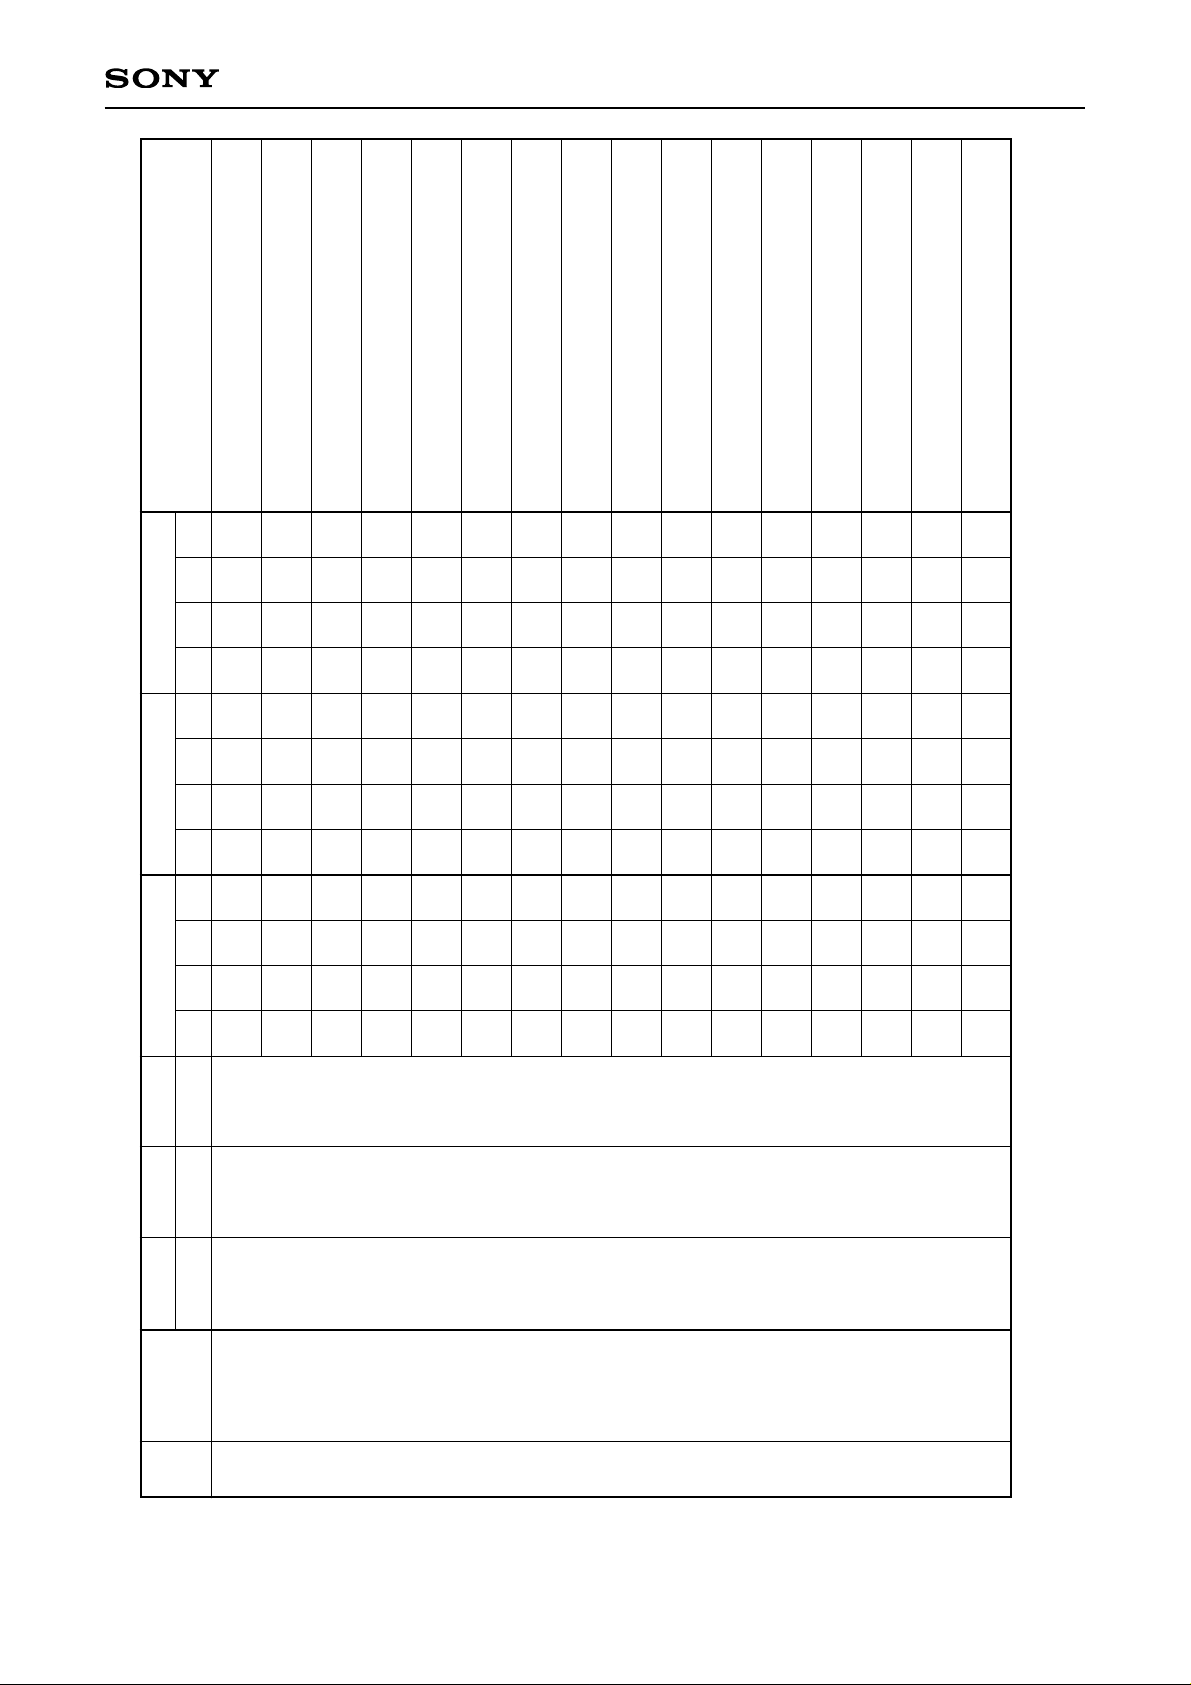
Command Table ($343X)
Page 22
– 22 –
CXD2598Q
KRAM DATA (K40)
TRACKING HOLD FILTER INPUT GAIN
KRAM DATA (K41)
TRACKING HOLD FILTER A-H
KRAM DATA (K42)
TRACKING HOLD FILTER A-L
KRAM DATA (K43)
TRACKING HOLD FILTER B-H
KRAM DATA (K44)
TRACKING HOLD FILTER B-L
KRAM DATA (K45)
TRACKING HOLD FILTER OUTPUT GAIN
KRAM DATA (K46)
TRACKING HOLD INPUT GAIN (when THSK = 1 TGup2)
KRAM DATA (K47)
NOT USED
KRAM DATA (K48)
FOCUS HOLD FILTER INPUT GAIN
KRAM DATA (K49)
FOCUS HOLD FILTER A-H
KRAM DATA (K4A)
FOCUS HOLD FILTER A-L
KRAM DATA (K4B)
FOCUS HOLD FILTER B-H
KRAM DATA (K4C)
FOCUS HOLD FILTER B-L
KRAM DATA (K4D)
FOCUS HOLD FILTER OUTPUT GAIN
KRAM DATA (K4E)
NOT USED
KRAM DATA (K4F)
NOT USED
0
0
0
0
0
0
0
0
1
1
1
1
1
1
1
1
0
0
0
0
1
1
1
1
0
0
0
0
1
1
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD7
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD6
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD5
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD4
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD3
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD2
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD1
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
KD0
3 0 0 1 1 0 1 0 0 0 1 0 0SELECT
Register
Command
Address 1
D23 to D20
Address 2
D19 to D16
Address 3
D15 to D12
Address 4
D11 D10 D9 D8
Data 1
D7 D6 D5 D4
Data 2
D3 D2 D1 D0
Command Table ($344X)
Page 23
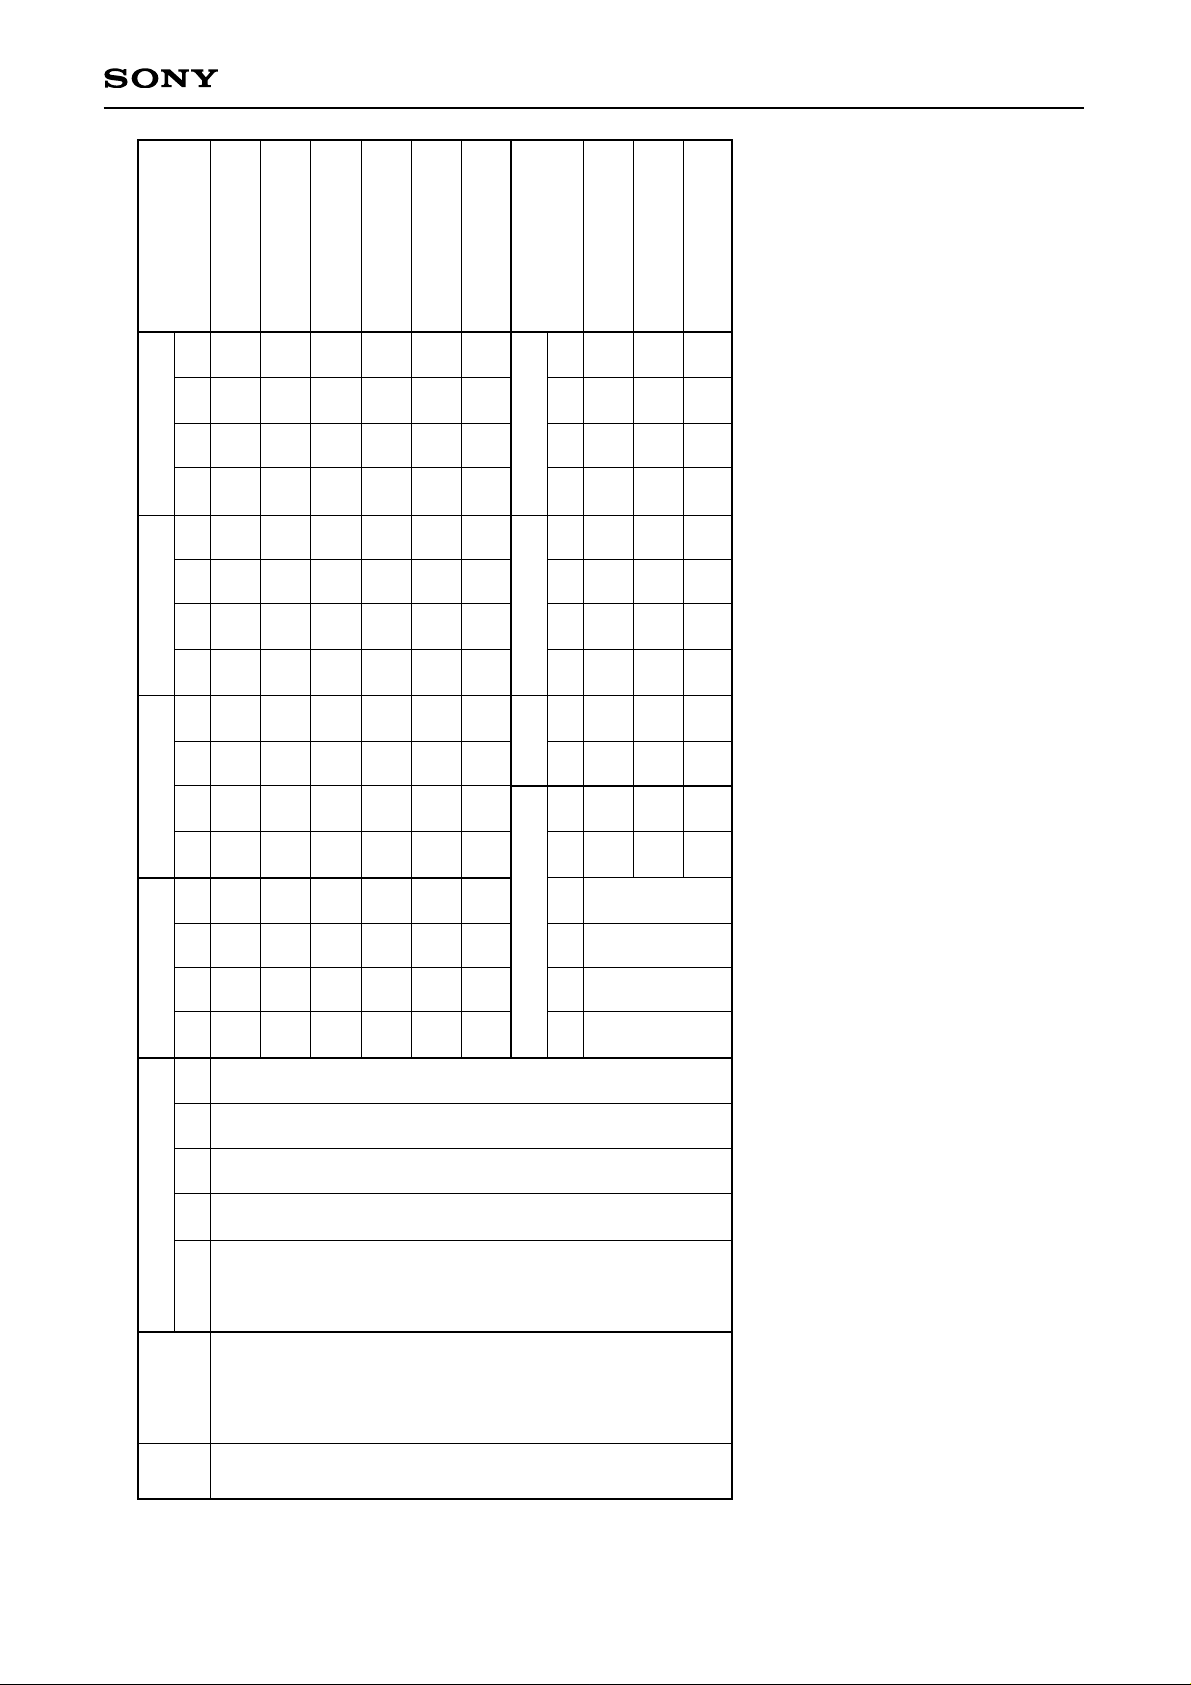
– 23 –
CXD2598Q
0
0
1
0
PGFS, PFOK, RFAC
DOUT
Booster Surf Brake
Booster
FCS Bias Limit
FCS Bias Data
Traverse Center Data
3
1
1
1
1
1
1
1
0
0
0
1
1
1
1
0
1
1
0
0
1
1
0
0
1
0
1
0
1
PGFS1
A/D
SEL
SFBK1
THBON
0
0
1
0
0
PGFS0
COPY
EN
SFBK2
FHBON
0
0
0
1
0
RFOK1
EMPH
D
0
TLB1ON
0
0
FBL9
FB9
TV9
RFOK0
CAT
b8
0
FLB1ON
0
0
FBL8
FB8
TV8
0
DOUT
EN1
0
TLB2ON
0
0
FBL7
FB7
TV7
0
DOUT
DMUT
0
0
0
0
FBL6
FB6
TV6
0
DOUT
WOD
0
HBST1
0
0
FBL5
FB5
TV5
0
WIN
EN
0
HBST0
0
0
FBL4
FB4
TV4
0
DOUT
EN2
0
LB1S1
0
0
FBL3
FB3
TV3
0
0
0
LB1S0
0
0
FBL2
FB2
TV2
0
0
0
LB2S1
0
0
FBL1
FB1
TV1
0
0
0
LB2S0
0
0
—
—
TV0
SELECT
Register
Command
Address 1
D23 to D20
D19
D18 D17 D16
Address 2
D15
D15 D14
D13 D12 D11 D10 D9 D8 D7 D6 D5 D4 D1 D0D3 D2
Data 3Data 2Data 1Address 2
D14 D13 D12
Data 1
D11 D10 D9 D8
Data 2
D7 D6 D5 D4
Data 3
D3 D2 D1 D0
Command Table ($348X to 34FX)
—: Don’t care
0 0 1 1
Page 24

– 24 –
CXD2598Q
FCS search, AGF
TRK jump, AGT
FZC, AGC, SLD move
DC measure, cancel
Serial data read out
FCS Bias, Gain,
Surf jump/brake
Mirr, DFCT, FOK
TZC, Cout, Bottom, Mirr
SLD filter
Filter
Clock, others
3
FT1
TDZC
FZSH
VCLM
DAC
0
SFO2
COSS
SFID
F1NM
0
1
0
1
0
1
0
1
0
1
0
1
0
1
1
0
0
1
1
0
0
1
1
1
1
1
0
0
0
0
1
1
1
1
0
0
0
1
1
1
1
1
1
1
1
FT0
DTZC
FZSL
VCLC
SD6
FBON
SFO1
COTS
SFSK
F1DM
AGG4
FS5
TJ5
SM5
FLM
SD5
FBSS
SDF2
CETZ
THID
F3NM
XT4D
FS4
TJ4
SM4
FLC0
SD4
FBUP
SDF1
CETF
THSK
F3DM
XT2D
FS3
TJ3
SM3
RFLM
SD3
FBV1
MAX2
COT2
0
TINM
0
FS2
TJ2
SM2
RFLC
SD2
FBV0
MAX1
COT1
TLD2
TIUM
DRR2
FS1
TJ1
SM1
AGF
SD1
0
SFOX
MOT2
TLD1
T3NM
DRR1
FS0
TJ0
SM0
AGT
SD0
TJD0
BTF
0
TLD0
T3UM
DRR0
FTZ
SFJP
AGS
DFSW
0
FPS1
D2V2
BTS1
0
DF1S
0
FG6
TG6
AGJ
LKSW
0
FPS0
D2V1
BTS0
0
TLCD
ASFG
FG5
TG5
AGGF
TBLM
0
TPS1
D1V2
MRC1
0
0
FTQ
FG4
TG4
AGGT
TCLM
0
TPS0
D1V1
MRC0
0
LKIN
LPAS
FG3
TG3
AGV1
FLC1
0
0
RINT
0
0
COIN
0
FG2
TG2
AGV2
TLC2
0
SJHD
0
0
0
MDFI
0
FG1
TG1
AGHS
TLC1
0
INBK
0
0
0
MIRI
AGHF
FG0
TG0
AGHT
TLC0
0
MTI0
0
0
0
XT1D
ASOT
SELECT
Register
Command
Address
D23 to D20 D19 D18 D17 D16
Data 1
D15 D14 D13 D12
Data 2
D11 D10 D9 D8
Data 3
D7 D6 D5 D4
Data 4
D3 D2 D1 D0
0 0 1 1
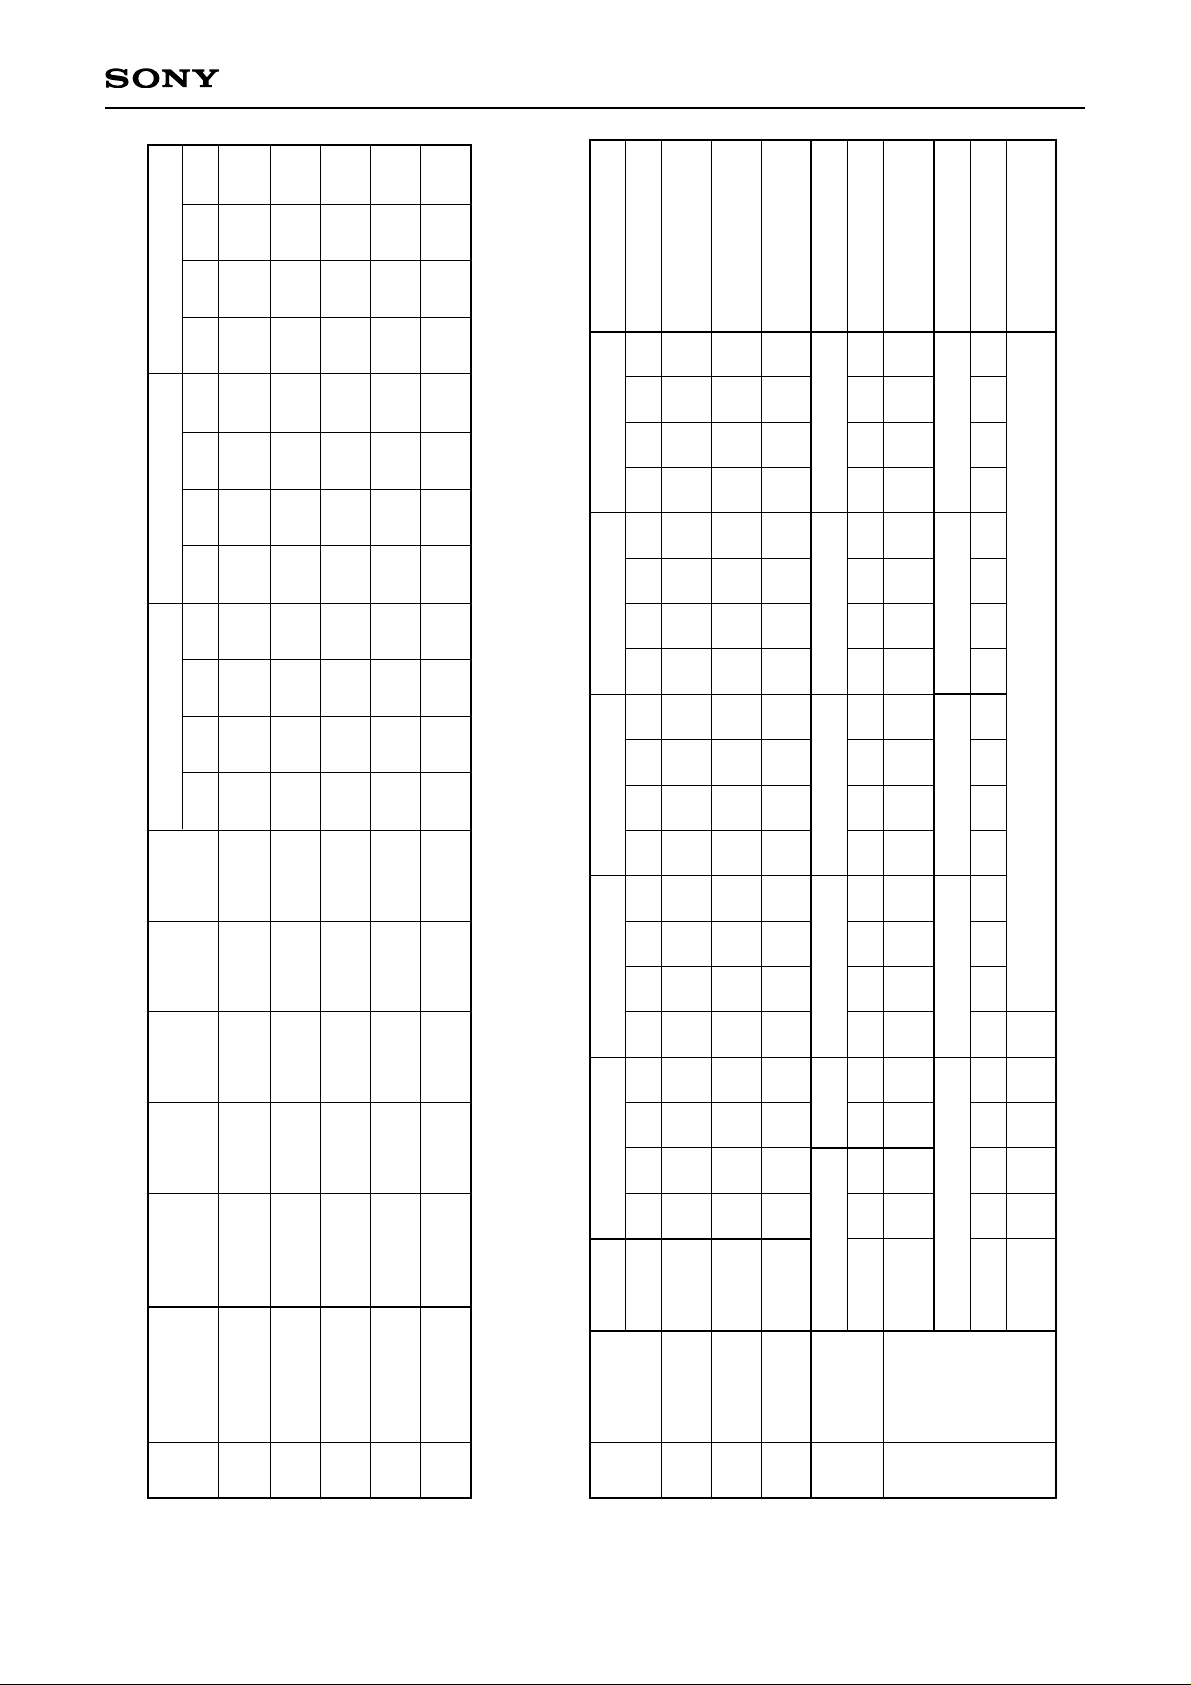
Command Table ($35X to 3FX)
Page 25

– 25 –
CXD2598Q
Auto sequence
Blind (A, E),
Brake (B),
Overflow (C, G)
Sled KICK,
BRAKE (D),
KICK (F)
Auto sequence (N)
track jump
count setting
MODE
specification
Function
specification
Audio CTRL
Traverse monitor
counter setting
Spindle servo
coefficient setting
CLV CTRL
SPD mode
0
0
0
0
1
1
1
1
1
1
1
1
1
1
1
0
0
0
0
1
1
1
0
0
1
1
0
0
1
1
0
0
1
0
1
0
1
0
1
0
1
0
1
0
AS3
TR3
SD3
32768
CD-
ROM
1
VARI
ON
32768
Gain
MDP1
0
CM3
AS2
TR2
SD2
16384
DOUT
Mute
DSPB
ON/OFF
VARI
USE
16384
Gain
MDP0
TB
CM2
AS1
TR1
SD1
8192
DOUT
Mute-F
ASEQ
ON/OFF
Mute
8192
Gain
MDS1
TP
CM1
AS0
TR0
SD0
4096
WSEL
1
ATT
4096
Gain
MDS0
CLVS
Gain
CM0
MT3
0
KF3
2048
VCO
SEL1
BiliGL
MAIN
PCT1
2048
Gain
DCLV1
VP7
EPWM
MT2
0
KF2
1024
ASHS
BiliGL
SUB
PCT2
1024
Gain
DCLV0
VP6
SPDC
MT1
0
KF1
512
SOCT0
FLFC
MCSL
512
PCC1
VP5
ICAP
MT0
0
KF0
256
VCO
SEL2
XWOC
SOC2
256
PCC0
VP4
SFSL
LSSL
0
0
128
KSL3
DAC
EMO
DCOF
128
SFP3
VP3
VC2C
0
0
0
64
KSL2
DAC
ATT
FMUT
64
SFP2
VP2
HIFC
0
0
0
32
KSL1
SYCOF
BSBST
32
SFP1
VP1
LPWR
0
0
0
16
KSL0
0
BBST
16
SFP0
VP0
VPON
—
—
—
8
0
PLM3
ATTCH
SEL
8
SRP3
VP
CTL1
Gain
CAV1
—
—
—
4
0
PLM2
ATD10
4
SRP2
VP
CTL0
Gain
CAV0
—
—
—
2
XVCO2
THRU
PLM1
ATD9
2
SRP1
0
0
—
—
—
1
0
PLM0
ATD8
1
SRP0
0
INV
VPCO
4
5
6
7
8
9
A
B
C
D
E
Register
Command
Address
D3 D2 D1 D0 D3 D2 D1 D0 D3 D2 D1 D0 D3 D2 D1 D0 D3 D2 D1 D0
Data 1 Data 2 Data 3 Data 4
Command Table ($4X to EX)
—: Don’t care
Page 26
– 26 –
CXD2598Q
FOCUS SERVO OFF,
0V OUT
TRACKING GAIN UP
FILTER SELECT 1
TRACKING SERVO OFF
SLED SERVO OFF
SLED KICK LEVEL
(±1 × basic value) (Default)
KRAM DATA
($3400XX to $344fXX)
0
0
0
0
0
0
0
0
0
0
1
0
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
—
0
1
2
0 0 0 0
0 0 0 1
0 0 1 0
FOCUS
CONTROL
TRACKING
CONTROL
TRACKING
MODE
Register
Command
Address
D23 to D20
Data 1
D19 D18 D17 D16
Data 2
D15 D14 D13 D12
Data 3
D11 D10 D9 D8
Data 4
D7 D6 D5 D4
Data 5
D3 D2 D1 D0
Register
Command
3 SELECT
Address
D23 to D20
0 0 1 1
0 0 1 1 0 1 0 0 0
See "Coefficient ROM Preset Values Table".
0 0 0 0 — — — — — — — — — — — — — — — —
Data 1
D19 D18 D17 D16
Data 2
D15 D14 D13 D12
Data 3
D11 D10 D9 D8
Data 4
D7 D6 D5 D4
Data 5
D3 D2 D0 D0
Address 1
D23 to D20 D19 D18 D17 D16
Address 2
D15 D14 D13 D12
Address 3
D11 D10 D9 D8
Data 1
D7 D6 D5 D4
Data 2
D3 D2 D0 D0
§1-3. CPU Command Presets
Command Preset Table ($0X to 34X)
—: Don’t care
MODE
specification
1 0 0 08
Function
specification
Audio CTRL
Traverse monitor
counter setting
Spindle servo
coefficient setting
1 0 0 1
1 0 1 0
1 0 1 1
9
A
B
C
Register
Command
Address Data 1
Data 2
Data 3
Data 4
—: Don’t care
ERC4
SCOR
SEL
SCSY SOCT1 TXON
TXOUT OUTLI OUTL0
DAC
SMUTL
ATD7
0
EDC7
DAC
SMUTR
ATD6
LRMIX
EDC6
ZMUT
ATD5
MTSL1
EDC5
ZDPL
ATD4
MTSL0
EDC4
0
ATD3
—
EDC3
0
ATD2
—
EDC2
0
ATD1
—
EDC1
0
ATD0
—
EDC0
D3 D2 D1 D0 D3 D2 D1 D0
Data 5 Data 6
FSTIN 0 OUTL2 0
DIV4 0 0 0
D3 D2 D1 D0
Data 7
Command Table ($4X to EX) cont.
Page 27
– 27 –
CXD2598Q
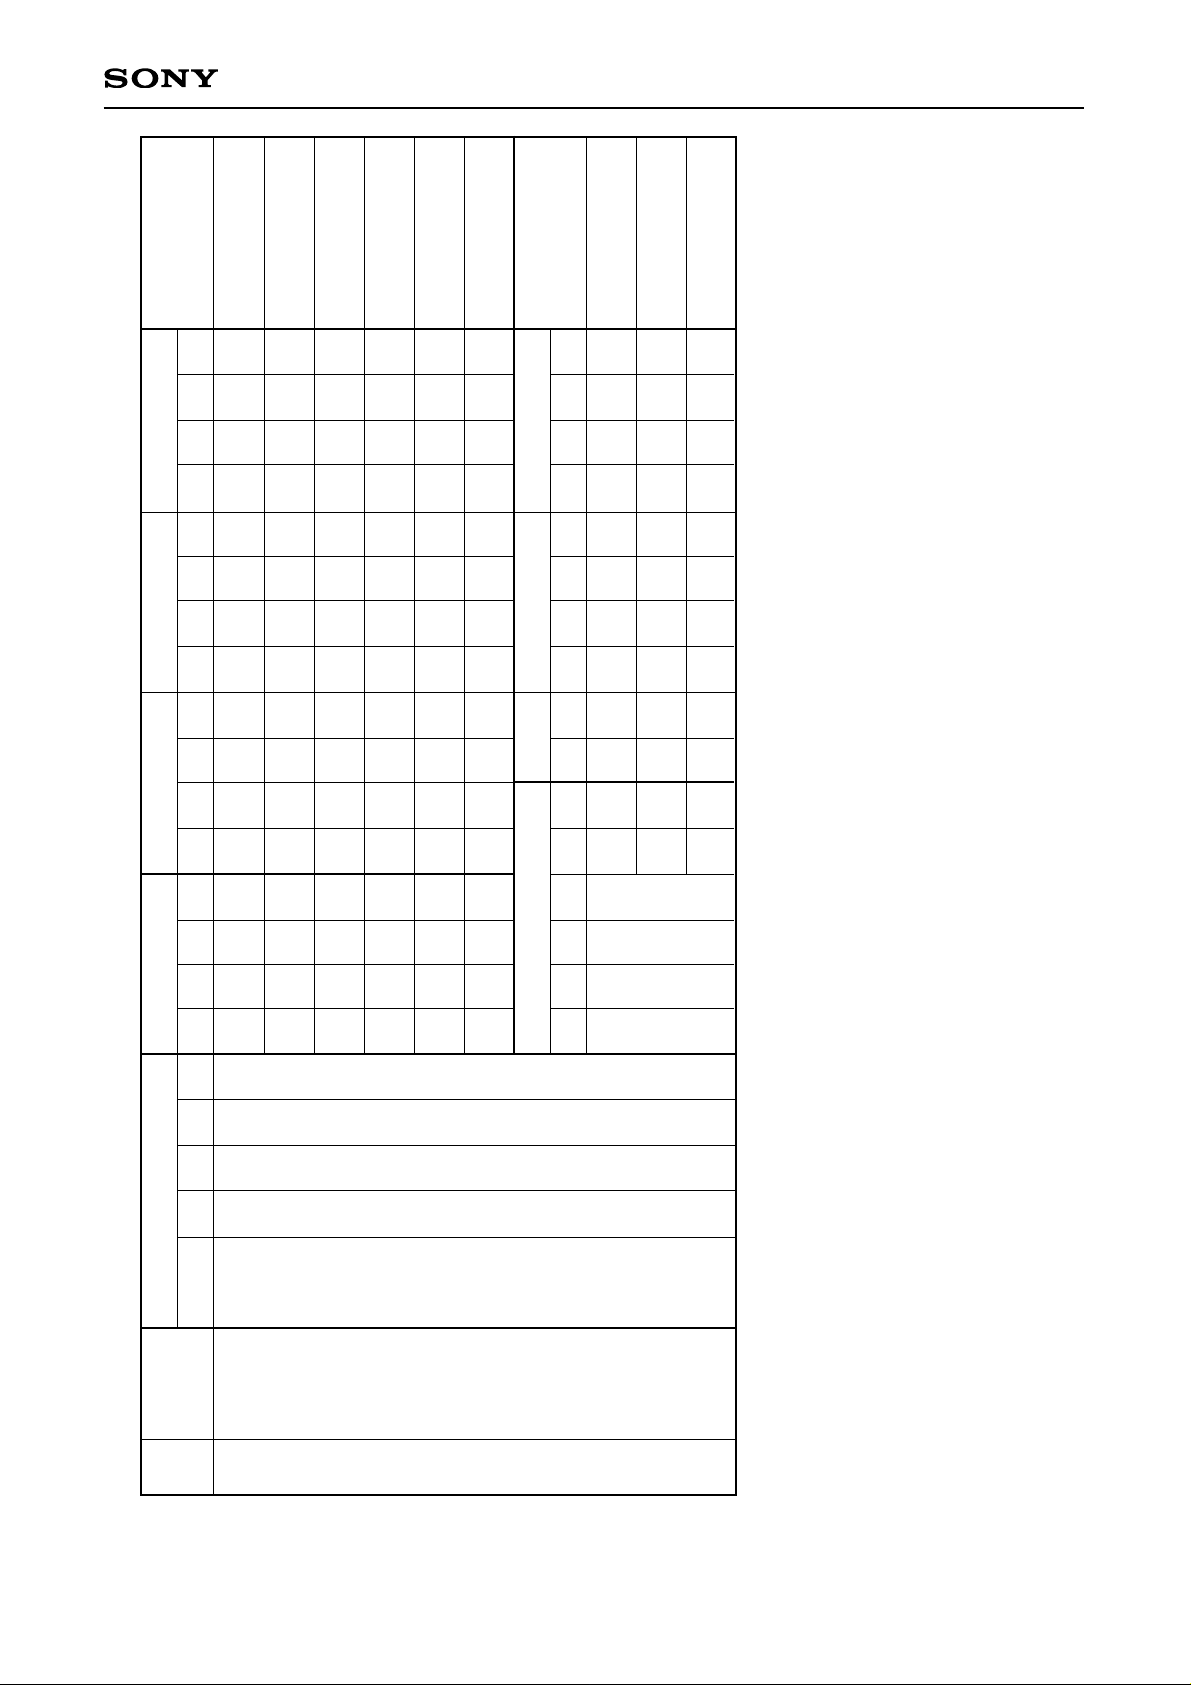
Command Preset Table ($348X to 34FX)
0010
PGFS, PFOK, RFAC
DOUT
Booster Surf Brake
Booster
FCS Bias Limit
FCS Bias Data
Traverse Center Data
3
1
1
1
1
1
1
1
0
0
0
1
1
1
1
0
1
1
0
0
1
1
0
0
1
0
1
0
1
0
0
0
0
0
0
1
0
0
0
0
0
0
0
0
0
1
0
0
0
0
0
0
0
0
0
0
0
1
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
1
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
1
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
SELECT
Register
Command
Address 1
D23 to D20 D19 D18 D17 D16
Address 2
D15
D15 D14 D13 D12 D11 D10 D9 D8 D7 D6 D5 D4 D1 D0D3 D2
Data 3Data 2Data 1Address 2
D14 D13 D12
Data 1
D11 D10 D9 D8
Data 2
D7 D6 D5 D4
Data 3
D3 D2 D1 D0
0 0 1 1
Page 28
– 28 –
CXD2598Q
FCS search, AGF
TRK jump, AGT
FZC, AGC, SLD move
DC measure, cancel
Serial data read out
FCS Bias, Gain,
Surf jump/brake
Mirr, DFCT, FOK
TZC, Cout, Bottom, Mirr
SLD filter
Filter
Clock, others
3
0
0
0
0
0
0
1
0
0
0
0
1
0
1
0
1
0
1
0
1
0
1
0
1
1
0
0
1
1
0
0
1
1
1
1
1
0
0
0
0
1
1
1
1
0
0
0
1
1
1
1
1
1
1
1
1
0
1
0
0
0
1
0
0
0
0
0
0
0
0
0
0
1
0
0
0
0
1
0
1
0
0
0
0
0
0
0
0
1
1
0
0
0
0
0
0
0
0
0
0
1
0
0
0
0
0
0
0
0
0
0
1
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
1
0
0
0
0
1
0
0
0
0
0
0
0
0
0
1
0
0
0
0
1
1
1
0
0
0
0
0
0
0
0
0
0
1
0
0
0
1
0
0
0
0
1
1
1
0
0
0
0
0
0
0
0
1
1
0
0
0
0
0
0
0
0
0
0
1
1
0
0
0
0
0
0
0
0
1
0
0
0
0
0
0
0
0
0
0
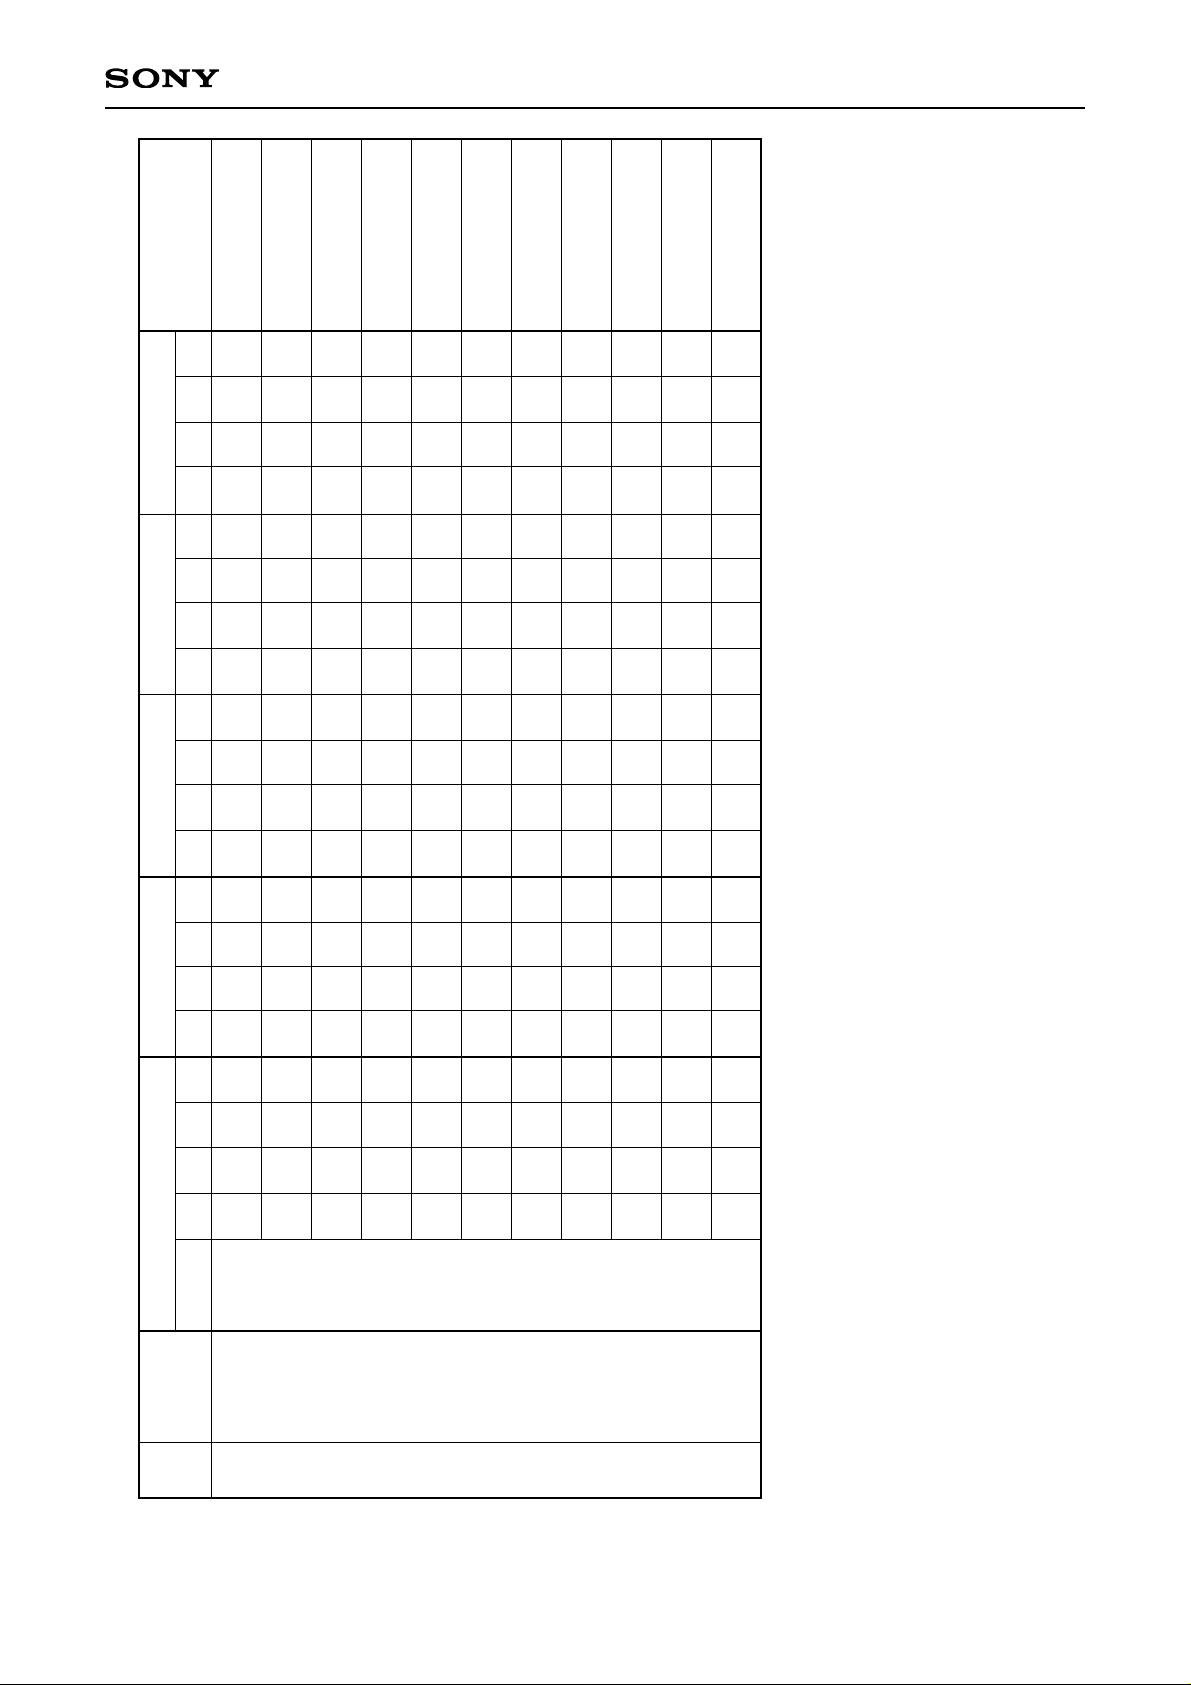
SELECT
Register
Command
Address
D23 to D20 D19 D18 D17 D16
Data 1
D15 D14 D13 D12
Data 2
D11 D10 D9 D8
Data 3
D7 D6 D5 D4
Data 4
D3 D2 D1 D0
0 0 1 1
Command Preset Table ($35X to 3FX)
Page 29
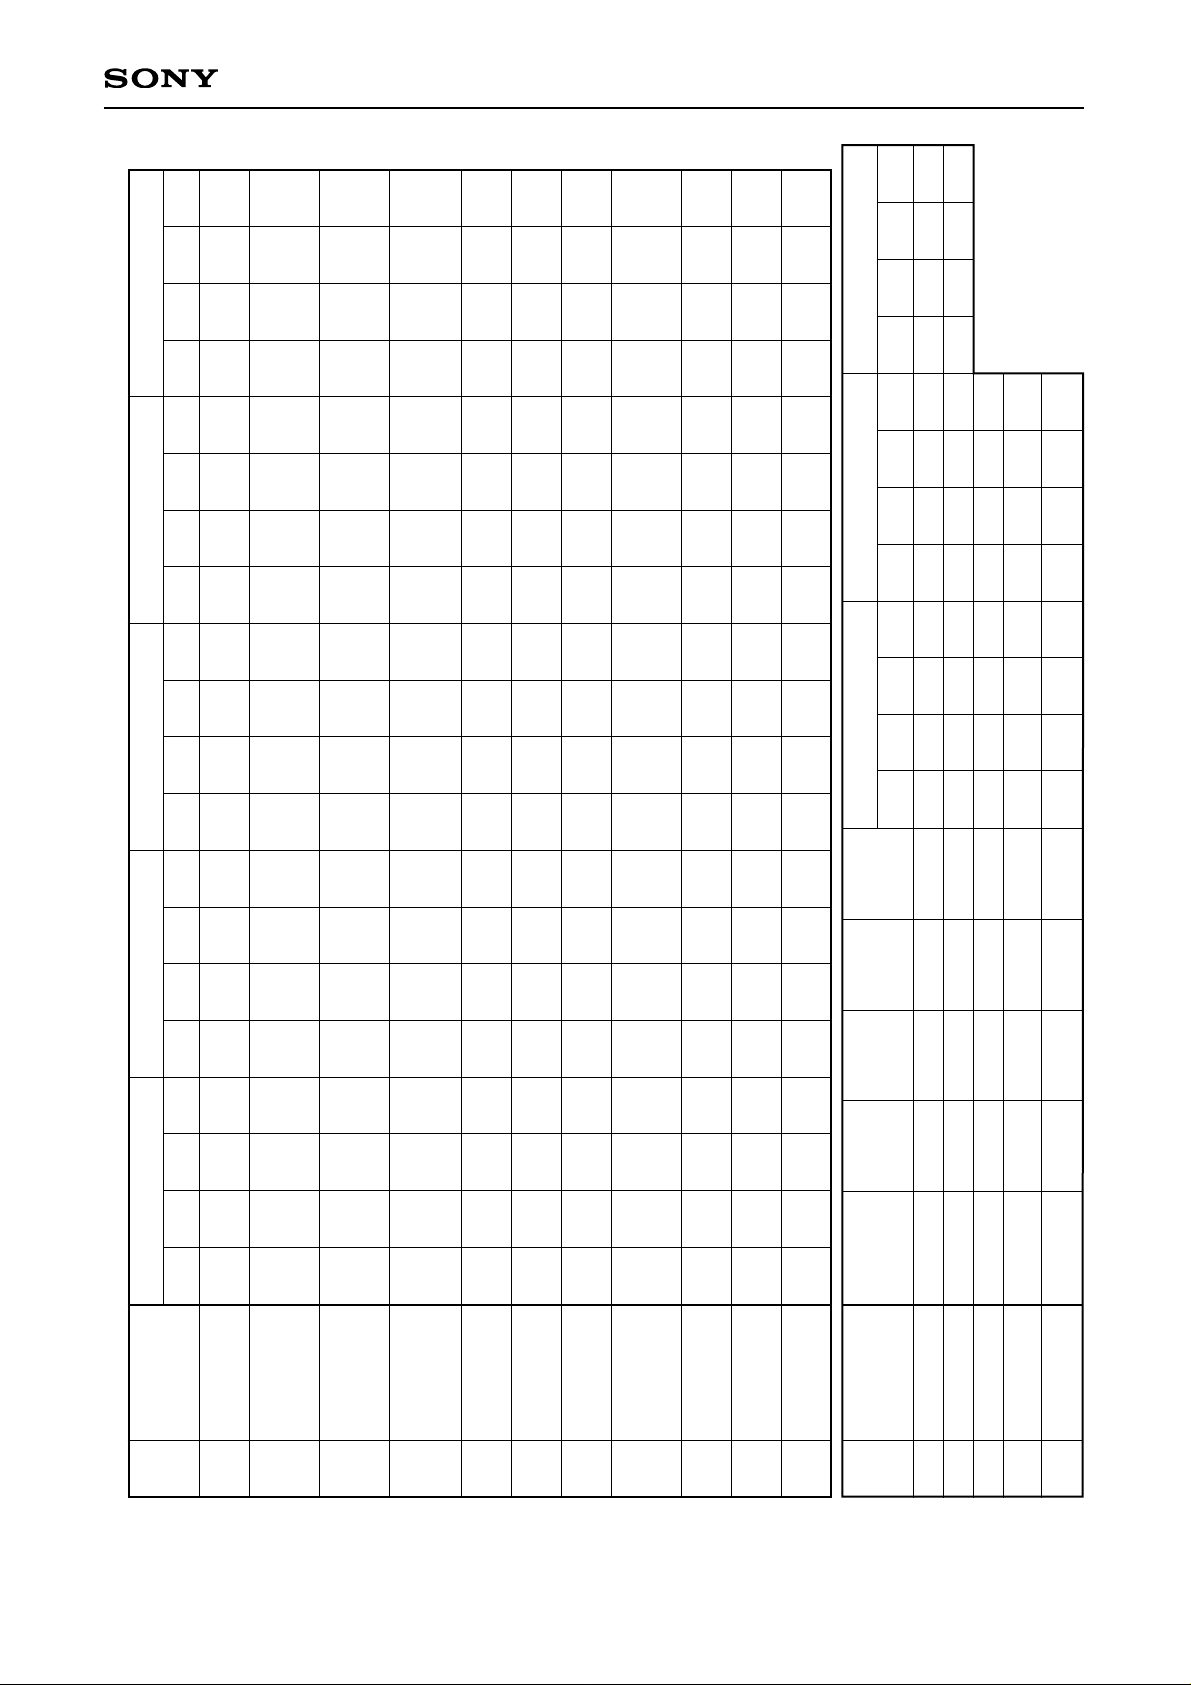
– 29 –
CXD2598Q
Auto sequence
Blind (A, E),
Brake (B),
Overflow (C, G)
Sled KICK,
BRAKE (D),
KICK (F)
Auto sequence (N)
track jump count
setting
MODE
specification
Function
specification
Audio CTRL
Traverse monitor
counter setting
Spindle servo
coefficient setting
CLV CTRL
SPD mode
0
0
0
0
1
1
1
1
1
1
1
1
1
1
1
0
0
0
0
1
1
1
0
0
1
1
0
0
1
1
0
0
1
0
1
0
1
0
1
0
1
0
1
0
0
0
0
0
0
1
0
0
0
0
0
0
1
1
0
0
0
0
0
0
0
0
0
0
1
0
0
0
1
0
0
0
0
0
1
1
0
0
1
1
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
1
0
1
0
1
0
0
0
0
0
0
0
0
0
0
0
1
0
0
0
0
0
0
0
0
0
0
1
0
0
0
0
0
0
1
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
—
—
—
0
0
1
0
0
0
0
0
—
—
—
0
0
0
1
0
0
0
0
—
—
—
0
0
0
0
0
1
0
0
—
—
—
0
0
1
0
0
1
0
0
4
5
6
7
8
9
A
B
C
D
E
Register
Command
Address
D3 D2 D1 D0 D3 D2 D1 D0 D3 D2 D1 D0 D3 D2 D1 D0 D3 D2 D1 D0
Data 1 Data 2 Data 3 Data 4
Command Preset Table ($4X to EX)
—: Don’t care
MODE specification
Function specification
Audio CTRL
Traverse monitor
counter setting
Spindle servo
coefficient setting
1 0 0 0
1 0 0 1
1 0 1 0
1 0 1 1
1 1 0 0
8
9
A
B
C
Register
Command
Address Data 1
Data 2
Data 3
Data 4
D3 D2 D1 D0 D3 D2 D1 D0
Data 5 Data 6
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
0
—
0
0
0
0
—
0
0
0
0
—
0
0
0
0
—
0
D3 D2 D1 D0
Data 7
0
0
0
0
0
0
0
0
Page 30
– 30 –
CXD2598Q
<Coefficient ROM Preset Values Table (1)>
ADDRESS
K00
K01
K02
K03
K04
K05
K06
K07
K08
K09
K0A
K0B
K0C
K0D
K0E
K0F
E0
81
23
7F
6A
10
14
30
7F
46
81
1C
7F
58
82
7F
SLED INPUT GAIN
SLED LOW BOOST FILTER A-H
SLED LOW BOOST FILTER A-L
SLED LOW BOOST FILTER B-H
SLED LOW BOOST FILTER B-L
SLED OUTPUT GAIN
FOCUS INPUT GAIN
SLED AUTO GAIN
FOCUS HIGH CUT FILTER A
FOCUS HIGH CUT FILTER B
FOCUS LOW BOOST FILTER A-H
FOCUS LOW BOOST FILTER A-L
FOCUS LOW BOOST FILTER B-H
FOCUS LOW BOOST FILTER B-L
FOCUS PHASE COMPENSATE FILTER A
FOCUS DEFECT HOLD GAIN
K10
K11
K12
K13
K14
K15
K16
K17
K18
K19
K1A
K1B
K1C
K1D
K1E
K1F
K20
K21
K22
K23
K24
K25
K26
K27
K28
K29
K2A
K2B
K2C
K2D
K2E
K2F
4E
32
20
30
80
77
80
77
00
F1
7F
3B
81
44
7F
5E
FOCUS PHASE COMPENSATE FILTER B
FOCUS OUTPUT GAIN
ANTI SHOCK INPUT GAIN
FOCUS AUTO GAIN
HPTZC / Auto Gain HIGH PASS FILTER A
HPTZC / Auto Gain HIGH PASS FILTER B
ANTI SHOCK HIGH PASS FILTER A
HPTZC / Auto Gain LOW PASS FILTER B
Fix
∗
TRACKING INPUT GAIN
TRACKING HIGH CUT FILTER A
TRACKING HIGH CUT FILTER B
TRACKING LOW BOOST FILTER A-H
TRACKING LOW BOOST FILTER A-L
TRACKING LOW BOOST FILTER B-H
TRACKING LOW BOOST FILTER B-L
82
44
18
30
7F
46
81
3A
7F
66
82
44
4E
1B
00
00
TRACKING PHASE COMPENSATE FILTER A
TRACKING PHASE COMPENSATE FILTER B
TRACKING OUTPUT GAIN
TRACKING AUTO GAIN
FOCUS GAIN DOWN HIGH CUT FILTER A
FOCUS GAIN DOWN HIGH CUT FILTER B
FOCUS GAIN DOWN LOW BOOST FILTER A-H
FOCUS GAIN DOWN LOW BOOST FILTER A-L
FOCUS GAIN DOWN LOW BOOST FILTER B-H
FOCUS GAIN DOWN LOW BOOST FILTER B-L
FOCUS GAIN DOWN PHASE COMPENSATE FILTER A
FOCUS GAIN DOWN DEFECT HOLD GAIN
FOCUS GAIN DOWN PHASE COMPENSATE FILTER B
FOCUS GAIN DOWN OUTPUT GAIN
NOT USED
NOT USED
DATA CONTENTS
∗
Fix indicates that normal preset values should be used.
Page 31

– 31 –
CXD2598Q
<Coefficient ROM Preset Values Table (2)>
ADDRESS
K30
K31
K32
K33
K34
K35
K36
K37
K38
K39
K3A
K3B
K3C
K3D
K3E
K3F
80
66
00
7F
6E
20
7F
3B
80
44
7F
77
86
0D
57
00
SLED INPUT GAIN (Only when TRK Gain Up2 is accessed with SFSK = 1.)
ANTI SHOCK LOW PASS FILTER B
NOT USED
ANTI SHOCK HIGH PASS FILTER B-H
ANTI SHOCK HIGH PASS FILTER B-L
ANTI SHOCK FILTER COMPARATE GAIN
TRACKING GAIN UP2 HIGH CUT FILTER A
TRACKING GAIN UP2 HIGH CUT FILTER B
TRACKING GAIN UP2 LOW BOOST FILTER A-H
TRACKING GAIN UP2 LOW BOOST FILTER A-L
TRACKING GAIN UP2 LOW BOOST FILTER B-H
TRACKING GAIN UP2 LOW BOOST FILTER B-L
TRACKING GAIN UP PHASE COMPENSATE FILTER A
TRACKING GAIN UP PHASE COMPENSATE FILTER B
TRACKING GAIN UP OUTPUT GAIN
NOT USED
K40
K41
K42
K43
K44
K45
K46
K47
K48
K49
K4A
K4B
K4C
K4D
K4E
K4F
04
7F
7F
79
17
6D
00
00
02
7F
7F
79
17
54
00
00
TRACKING HOLD FILTER INPUT GAIN
TRACKING HOLD FILTER A-H
TRACKING HOLD FILTER A-L
TRACKING HOLD FILTER B-H
TRACKING HOLD FILTER B-L
TRACKING HOLD FILTER OUTPUT GAIN
TRACKING HOLD FILTER INPUT GAIN (Only when TRK Gain Up2 is accessed with THSK = 1.)
NOT USED
FOCUS HOLD FILTER INPUT GAIN
FOCUS HOLD FILTER A-H
FOCUS HOLD FILTER A-L
FOCUS HOLD FILTER B-H
FOCUS HOLD FILTER B-L
FOCUS HOLD FILTER OUTPUT GAIN
NOT USED
NOT USED
DATA CONTENTS
Page 32

– 32 –
CXD2598Q
§1-4. Description of SENS Signals
SENS output
Microcomputer serial
register
(latching not required)
$0X
$1X
$2X
$30 to 37
$38
$38
$3904
$3908
$390C
$391C
$391D
$391F
$3A
$3B to 3F
$4X
$5X
$6X
$AX
$BX
$CX
$EX
$7X, 8X, 9X,
DX, FX
Z
Z
Z
Z
Z
Z
Z
Z
Z
Z
Z
Z
Z
Z
Z
Z
Z
GFS
COMP
COUT
OV64
Z
FZC
AS
TZC
SSTP
AGOK
∗
XAVEBSY
∗
TE Avrg Reg.
FE Avrg Reg.
VC Avrg Reg.
TRVSC Reg.
FB Reg.
RFDC Avrg Reg.
FBIAS Count STOP
SSTP
XBUSY
FOK
0
GFS
COMP
COUT
OV64
0
—
—
—
—
—
—
9 bits
9 bits
9 bits
9 bits
9 bits
8 bits
—
—
—
—
—
—
—
—
—
—
ASEQ = 0 ASEQ = 1 Output data length
∗
$38 outputs AGOK during AGT and AGF command settings, and XAVEBSY during AVRG measurement.
SSTP is output in all other cases.
Page 33

– 33 –
CXD2598Q
Description of SENS Signals
The SENS pin is high impedance.
Low while the auto sequencer is in operation, high when operation terminates.
Outputs the same signal as the FOK pin.
High for "focus OK".
High when the regenerated frame sync is obtained with the correct timing.
Counts the number of tracks set by Reg.B.
High when Reg.B is latched, low when COUT is counted for the initial Reg.B number.
Counts the number of tracks set by Reg.B.
High when Reg.B is latched, toggles each time COUT is counted for the Reg.B number.
While $44 and $45 are being executed, toggles with each COUT 8-count instead of the
Reg.B number.
Low when the EFM signal is lengthened by 64 channel clock pulses or more after passing
through the sync detection filter.
Z
XBUSY
FOK
GFS
COMP
COUT
OV64
SENS output
Page 34

– 34 –
CXD2598Q
§1-5. Description of Commands
The meaning of the data for each address is explained below.
$4X commands
Register name
4
Data 1
Command
Data 2
MAX timer value
Data 3
Timer range
AS3 AS2 AS1 AS0 MT3 MT2 MT1 MT0 LSSL 0 0 0
Command
Cancel
Fine Search
Focus-On
1 Track Jump
10 Track Jump
2N Track Jump
M Track Move
0
0
0
1
1
1
1
0
1
1
0
0
1
1
0
0
1
0
1
0
1
0
RXF
1
RXF
RXF
RXF
RXF
AS3 AS2 AS1 AS0
RXF = 0 Forward
RXF = 1 Reverse
• When the Focus-On command ($47) is canceled, $02 is sent and the auto sequence is interrupted.
• When the Track Jump commands ($44 to $45, $48 to $4D) are canceled, $25 is sent and the auto sequence
is interrupted.
• To disable the MAX timer, set the MAX timer value to 0.
$5X commands
MAX timer value
MT3
23.2ms
1.49s
11.6ms
0.74s
5.8ms
0.37s
2.9ms
0.18s
0
1
0
0
0
0
0
0
MT2 MT1 MT0 LSSL 0 0 0
Timer range
Timer TR3 TR2 TR1
TR0
Blind (A, E), Overflow (C, G)
Brake (B)
0.18ms
0.36ms
0.09ms
0.18ms
0.045ms
0.09ms
0.022ms
0.045ms
Page 35

– 35 –
CXD2598Q
Command
Data 1 Data 2
Data 3 Data 4
D3 D2 D1 D0 D3 D2 D1 D0 D3 D2 D1 D0 D3 D2 D1 D0
2152142132122112102928272625242322212
0
Auto sequence
track jump count setting
This command is used to set N when a 2N-track jump is executed, M when an M-track move is executed and
the jump count when fine search is executed for auto sequence.
• The maximum track count is 65,535, but note that with a 2N-track jump the maximum track jump count
depends on the mechanical limitations of the optical system.
• When the track jump count is from 0 to 15, the COUT signal is counted for 2N-track jumps and M-track
moves; when the count is 16 or over, the MIRR signal is counted. For fine search, the COUT signal is
counted.
$7X commands
Auto sequence track jump count setting
$6X commands
Register name
6
Data 1
KICK (D)
Data 2
KICK (F)
SD3 SD2 SD1 SD0 KF3 KF2 KF1 KF0
Timer SD3 SD2 SD1 SD0
When executing KICK (D)
$44 or $45
When executing KICK (D)
$4C or $4D
23.2ms
11.6ms
11.6ms
5.8ms
5.8ms
2.9ms
2.9ms
1.45ms
Timer KF3 KF2 KF1 KF0
KICK (F) 0.72ms 0.36ms 0.18ms 0.09ms
Page 36

– 36 –
CXD2598Q
∗
See mute conditions (1) and (3) to (5) under $AX commands for other mute conditions.
MD2
Other mute conditions
∗
DOUT Mute
DOUT Mute F
DOUT output
OFF
0dB
–∞dB
DA output for 48-bit slot
0dB
0dB
–∞dB
0dB
–∞dB
–∞dB
0
0
0
0
0
0
0
0
1
1
1
1
1
1
1
1
0
0
0
0
1
1
1
1
0
0
0
0
1
1
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
Command
Data 1
MODE
specification
CD-
ROM
DOUT
Mute
DOUT
Mute-F
WSEL
D3 D2 D1 D0
Data 2
VCO
SEL1
ASHS SOCT0
VCO
SEL2
D3 D2 D1 D0
$8X commands
Command bit
DOUT Mute = 1
DOUT Mute = 0
When Digital Out is on (MD2 pin = 1), DOUT output is muted.
When Digital Out is on, DOUT output is not muted.
Processing
Command bit
DOUT Mute F = 1
DOUT Mute F = 0
When Digital Out is on (MD2 pin = 1), DA output is muted.
DA output mute is not affected when Digital Out is either on or off.
Processing
Command bit
CDROM = 1
CDROM = 0
C2PO timing
1-3
1-3
CDROM mode; average value interpolation and pre-value hold are not performed.
Audio mode; average value interpolation and pre-value hold are performed.
Processing
Page 37
– 37 –
CXD2598Q
Command bit
Processing
VCOSEL1 = 0
VCOSEL1 = 1
Multiplier PLL VCO1 is set to normal speed.
Multiplier PLL VCO1 is set to approximately twice the normal speed.
Command bit
KSL3 KSL2
Processing
Output of multiplier PLL VCO1 is 1/1 frequency-divided.
Output of multiplier PLL VCO1 is 1/2 frequency-divided.
Output of multiplier PLL VCO1 is 1/4 frequency-divided.
Output of multiplier PLL VCO1 is 1/8 frequency-divided.
0
0
1
1
0
1
0
1
See above.
Command
Data 2
MODE
specification
VCO
SEL1
ASHS SOCT0
VCO
SEL2
D3 D2 D1 D0
Data 3
KSL3 KSL2 KSL1 KSL0
D3 D2 D1 D0
Command bit
Sync protection window width
WSEL = 1
WSEL = 0
±26 channel clock
±6 channel clock
Anti-rolling is enhanced.
Sync window protection is enhanced.
Application
∗
In normal-speed playback, channel clock = 4.3218MHz.
Command bit
Function
ASHS = 0
ASHS = 1
The command transfer rate from the auto sequencer to the DSSP block is set to normal speed.
The command transfer rate from the auto sequencer to the DSSP block is set to half speed.
∗
See "§4-8. CD-DSP Block Playback Speed" for settings.
Command bit
SOCT0 SOCT1
Processing
Sub-Q is output from the SQSO pin.
Various signals are output from the SQSO pin. Input the readout clock to SQCK.
(See Timing Chart 2-4.)
The error rate is output from the SQSO pin. Input the readout clock to SQCK.
(See Timing Chart 2-6.)
0
1
1
—
0
1
—: Don't care
Page 38

– 38 –
CXD2598Q
Command bit
Processing
VCOSEL2 = 0
VCOSEL2 = 1
Wide-band PLL VCO2 is set to normal speed.
Wide-band PLL VCO2 is set to approximately twice the normal speed.
Command bit
KSL1 KSL0
Processing
Output of wide-band PLL VCO2 is 1/1 frequency-divided.
Output of wide-band PLL VCO2 is 1/2 frequency-divided.
Output of wide-band PLL VCO2 is 1/4 frequency-divided.
Output of wide-band PLL VCO2 is 1/8 frequency-divided.
0
0
1
1
0
1
0
1
D3
0 0
VCO2
THRU
0 ERC4
SCOR
SEL
SCSY SOCT1 TXON TXOUT OUTL1 OUTL0
D2 D1 D0 D3 D2 D1 D0 D3 D2 D1 D0
Data 4 Data 5 Data 6
Command
MODE
specification
Command bit
VCO2 THRU = 0
Processing
V16M is output.
Wide-band EFM PLL clock can be input from the V16M pin.
∗
This command sets internal or external connection for the VCO2 used during CAV-W mode and variable
pitch mode.
VCO2 THRU = 1
Command bit
Processing
ERC4 = 0
ERC4 = 1
C2 error double correction is performed when DSPB = 1.
C2 error quadruple correction is performed even when DSPB = 1.
Command bit
Processing
SCOR SEL = 0
SCOR SEL = 1
WDCK signal is output.
GRSCOR (protected SCOR) is output.
∗
Used when outputting GRSCOR from the WDCK pin.
See the previous page.
Page 39
– 39 –
CXD2598Q
Command bit
TXON = 0
Processing
When CD TEXT data is not demodulated, set TXON to 0.
When CD TEXT data is demodulated, set TXON to 1.
∗
See "§4-14. CD TEXT Data Demodulation".
TXON = 1
Command bit
Processing
SCSY = 0
SCSY = 1
No processing.
GRSCOR (protected SCOR) synchronization is applied again.
∗
Used to resynchronize GRSCOR.
The rising edge signal of this command bit is used internally, so when resynchronizing GRSCOR, first return
the setting to 0 and then set to 1.
GRSCOR is the crystal accuracy SCOR signal obtained by removing the motor wow component.
This signal is synchronized with PCMDATA.
The resynchronization conditions are when GTOP = high or when the SCSY pin = high.
(Same as when SCSY = 1 is sent by the $8X command.)
Command bit
TXOUT = 0
Processing
Various signals except for CD TEXT are output from the SQSO pin.
CD TEXT data is output from the SQSO pin.
∗
See "§4-14. CD TEXT Data Demodulation".
TXOUT = 1
Command bit
OUTL1 = 0
Processing
XPCK, C4M, WDCK and FSTO are output.
V16M is output when VCO2 THRU = 0.
XPCK, C4M, WDCK and FSTO outputs are set to low.
V16M output is set to low when VCO2 THRU = 0.
OUTL1 = 1
Command bit
OUTL0 = 0
OUTL0 = 1
Processing
PCMD, BCK, LRCK and EMPH are output.
PCMD, BCK, LRCK and EMPH outputs are set to low.
Page 40

– 40 –
CXD2598Q
Command
Data 1
Function
specification
1
DSPB
ON-OFF
A.SEQ
ON-OFF
1
D3 D2 D1 D0
Data 2
BiliGL
MAIN
BiliGL
SUB
FLFC
D3 D2
D1
XWOC
D0
$9X commands
Command bit
DSPB = 0
DSPB = 1
Normal-speed playback, C2 error quadruple correction.
Double-speed playback, C2 error double correction. (quadruple correction when ERC4 = 1)
Processing
FLFC is normally 0.
Set FLFC to 1 in CAV-W mode for any playback speed.
Command bit
BiliGL SUB = 0
BiliGL SUB = 1
STEREO
SUB
MAIN
Mute
BiliGL MAIN = 0 BiliGL MAIN = 1
Definition of bilingual capable MAIN, SUB and STEREO
The left channel input is output to the left and right channels for MAIN.
The right channel input is output to the left and right channels for SUB.
The left and right channel inputs are output to the left and right channels, respectively, for STEREO.
Command bit
Processing
FSTIN = 0
FSTIN = 1
Servo block clock switching uses the internal connection. (Preset)
The clock with 2/3 frequency division for the XTLO pin is input to the servo block.
The FSTIO pin functions as an output pin for monitoring the servo block clock.
Servo block clock switching uses external input.
The FSTIO pin functions as an input pin.
Input the servo block clock from the FSTIO pin.
Command bit
Processing
OUTL2 = 0
OUTL2 = 1
WFCK is output.
WFCK is set to low.
Command
MODE
specification
Data 7
FSTIN 0 OUTL2 0
D3 D2 D1 D0
Page 41

– 41 –
CXD2598Q
Command
Data 3
Function
specification
DAC
EMPH
DAC
ATT
SYCOF 0
D3 D2 D1 D0
Command bit
DAC EMPH = 1
DAC EMPH = 0
Applies digital de-emphasis. The emphasis constants are τ1 = 50µs and τ 2 = 15µs
when Fs = 44.1kHz.
Turns digital de-emphasis off.
Processing
Command bit
DAC ATT = 1
DAC ATT = 0
Identical digital attenuation control is used for both the left and right channels. When
common attenuation data is specified, the attenuation values for the left channel are used.
Independent digital attenuation control is used for the left and right channels.
Processing
∗
This is used to resynchronize the DAC.
Command bit
Processing
DAC sync window opens.
DAC sync window does not open.
XWOC = 0
XWOC = 1
Command bit
SYCOF = 1
SYCOF = 0
LRCK asynchronous mode.
Normal operation.
Processing
∗
Set SYCOF = 0 in advance when setting the XWOC command of $9 to 0.
Page 42

– 42 –
CXD2598Q
PLM3
0
0
0
0
0
0
0
0
1
1
1
1
1
1
1
1
0
0
0
0
1
1
1
1
0
0
0
0
1
1
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
Mute
L
R
L + R
Mute
L
R
L + R
Mute
L
R
L + R
Mute
L
R
L + R
Mute
Mute
Mute
Mute
L
L
L
L
R
R
R
R
L + R
L + R
L + R
L + R
Mute
Reverse
Stereo
Mono
PLM2 PLM1 PLM0 Left channel output Right channel output Remarks
Note) The output data of L + R is (L + R)/2 to prevent overflow.
Command
Data 4
Function
specification
PLM3 PLM2 PLM1 PLM0
D3 D2 D1 D0
• DAC play mode
By controlling these command bits, the DAC output left channel and right channel can be output in 16
different combinations of left (L) channel, right (R) channel, left + right (L + R) channel, and mute.
The relationship between the commands and the outputs is shown in the table below.
Page 43

– 43 –
CXD2598Q
Command
Data 5
Function
specification
DAC
SMUTL
DAC
SMUTR
ZMUT ZDPL
D3 D2 D1 D0
Command bit
DAC SMUTL = 1
DAC SMUTL = 0
Left channel soft mute is on.
Left channel soft mute is off.
Processing
Command bit
DAC SMUTR = 1
DAC SMUTR = 0
Right channel soft mute is on.
Right channel soft mute is off.
Processing
Command bit
ZMUT = 1
ZMUT = 0
Zero detection mute is on.
Zero detection mute is off.
Processing
Command bit
ZDPL = 1
ZDPL = 0
LMUT and RMUT pins are high when muted.
LMUT and RMUT pins are low when muted.
Processing
∗
See "Mute flag output" for the mute flag output conditions.
Command
Data 6
Function
specification
0 0 0 0
D3 D2 D1 D0
Data 7
DIV4 0 0 0
D3 D2 D1 D0
Command bit
DIV4 = 0
DIV4 = 1
Digital PLL master clock, conventional mode. (Preset)
Digital PLL master clock, 2/3 mode.
Processing
This switches the digital PLL master clock.
Either the conventional mode or the 2/3 mode (2/3 of the conventional clock) can be selected.
Note) Do not set DIV4 = 1 when DSPB = 0.
Page 44

– 44 –
CXD2598Q
Command
Data 1
Audio CTRL
VARI
ON
VARI
USE
Mute ATT
D3 D2 D1 D0
Data 2
PCT1 PCT2
D3 D2
MCSL SOC2
D1 D0
$AX commands
Command bit
Mute = 0
Mute = 1
Mute off if other mute
conditions are not set.
Mute on.
Peak register reset.
Meaning
Command bit
ATT = 0
ATT = 1
Attenuation off.
–12dB
Meaning
Mute conditions
(1) When register A mute = 1.
(2) When Digital Out is on (MD2 pin = 1) and register 8 DOUT Mute F = 1.
(3) When GFS stays low for 35 ms or more (during normal-speed).
(4) When register 9 BiliGL MAIN = Sub = 1.
(5) When register A PCT1 = 1 and PCT2 = 0.
(1) to (3) perform zero-cross muting with a 1ms time limit.
Command bit
PCT1
0
0
1
1
PCT2
0
1
0
1
Normal mode
Level meter mode
Peak meter mode
Normal mode
× 0dB
× 0dB
Mute
× 0dB
C1: double; C2: quadruple
C1: double; C2: quadruple
C1: double; C2: double
C1: double; C2: double
Meaning PCM Gain
ECC error
correction ability
Description of level meter mode (see Timing Chart 1-4.)
• When the LSI is set to this mode, it performs digital level meter functions.
• When the 96-bit clock is input to SQCK, 96 bits of data are output to SQSO.
The initial 80 bits are Sub-Q data (see "§2. Subcode Interface"). The last 16 bits are LSB first, and consist of
15-bit PCM data (absolute values) and an L/R flag.
The final bit (L/R flag) is high when the PCM data is from the left channel and low when the data is from the
right channel.
• The PCM data is reset and the L/R flag is reversed after one readout.
Then the maximum value is measured until the next readout.
Command bit
VARION = 0
Processing
Variable pitch mode is off. (The internal clock uses the crystal reference.)
Variable pitch mode is on. (The internal clock uses the VCO2 reference.)VARION = 1
Command bit
VARIUSE = 0
Processing
Set VARIUSE = 0 when not using variable pitch mode.
Set VARIUSE = 1 when using variable pitch mode.
∗
See "$DX commands" for the variable pitch range and example of use.
VARIUSE = 1
Page 45
– 45 –
CXD2598Q
Description of peak meter mode (see Timing Chart 1-5.)
• When the LSI is set to this mode, the maximum PCM data value is detected regardless of if it comes from the
left or right channel.
The 96-bit clock must be input to SQCK to read out this data.
• When the 96-bit clock is input, 96 bits of data are output to SQSO and the value is reset in the LSI internal
register.
In other words, the PCM maximum value register is not reset by the readout.
• To reset the PCM maximum value register, set PCT1 = PCT2 = 0 or set the Mute command of $AX to 1.
• The Sub-Q absolute time is automatically controlled in this mode.
In other words, after the maximum value is generated, the absolute time for CRC to become OK is retained in
the memory. Normal operation is conducted for the relative time.
• The final bit (L/R flag) of the 96-bit data is normally 0.
• The pre-value hold and average value interpolation data are fixed to level (–∞) for this mode.
SENS output switching
• This command is used to output the SQSO pin signal from the SENS pin.
When SOC2 = 0, SENS output is performed as usual.
When SOC2 = 1, the SQSO pin signal is output from the SENS pin.
At this time, the readout clock is input to the SCLK pin.
Note) SOC2 should be switched when SQCK = SCLK = high.
Command bit
SOC2 = 0
SOC2 = 1
The SENS signal is output from the SENS pin as usual.
The SQSO pin signal is output from the SENS pin.
Processing
Command bit
MCSL = 1
MCSL = 0
DF/DAC block master clock selection. Crystal = 768Fs (33.8688MHz)
DF/DAC block master clock selection. Crystal = 384Fs (16.9344MHz)
Processing
Note) See "§4-9. DAC Block Playback Speed".
Page 46

– 46 –
CXD2598Q
Command
Data 3
Audio CTRL
DCOF FMUT BSBST BBSL
D3 D2 D1 D0
Command bit
DCOF = 1
DCOF = 0
DC offset is off.
DC offset is on.
Processing
Command bit
FMUT = 1
FMUT = 0
Forced mute is on.
Forced mute is off.
Processing
Command bit
BSBST = 1
BSBST = 0
Bass boost is on.
Bass boost is off.
Processing
Command bit
BBSL = 1
BBSL = 0
Bass boost is Max.
Bass boost is Mid.
Processing
∗
Set DC offset to off when zero detection mute is on.
Page 47

– 47 –
CXD2598Q
Data 4
D3
ATTCH
SEL
ATD10
ATD9 ATD8 ATD7 ATD6 ATD5 ATD4 ATD3 ATD2 ATD1 ATD0
Audio CTRL
D2 D1 D0 D3 D2 D1 D0 D3 D2 D1 D0
Data 5 Data 6
Attenuation data
400h
3FFh
3FEh
:
001h
000h
0dB
–0.0085dB
–0.017dB
:
–60.206dB
–∞
Audio output
The attenuation data consists of 11 bits each for the left and right channels, and the DAC ATT bit can be used to
control the left and right channels with common attenuation data. When common attenuation data is specified,
the left channel attenuation values are used.
The audio output from 001h to 400h is obtained using
the following equation:
Audio output = 20 log [dB]
Command bit
ATTCH SEL = 1
ATTCH SEL = 0
Right channel attenuation data can be set.
Left channel attenuation data can be set.
Processing
Command bit
ATD10 to 0 Attenuation data.
Meaning
Attenuation data
1024
Command
Page 48

– 48 –
CXD2598Q
$BX commands
This command sets the traverse monitor count.
Command
Data 1 Data 2
Data 3 Data 4
D3 D2 D1 D0 D3 D2 D1 D0 D3 D2 D1 D0 D3 D2 D1 D0
2152142132122112102928272625242322212
0
Traverse monitor
count setting
• When the set number of tracks are counted during fine search, the sled control for the traverse cycle control
goes off.
• The traverse monitor count is set to monitor the traverse status using the SENS outputs COMP and COUT.
Command bit
MTSL1 MTSL0
Output data
XUGF
MINT0
RFCK
XPCK
MNT1
XPCK
GFS
MNT2
XROF
C2PO
MNT3
GTOP
0
0
1
0
1
0
Command
Data 5
Traverse monitor
count setting
0
LRMIX
MTSL1 MTSL0
D3 D2 D1 D0
The monitor output is set as follows.
Command bit
LRMIX = 0
LRMIX = 1
LMUT and RMUT both operate normally.
The AND signal of the left channel and right channel zero detection flags is output from
the LMUT pin.
The OR signal of the left channel and right channel zero detection flags is output from
the RMUT pin.
Processing
Page 49
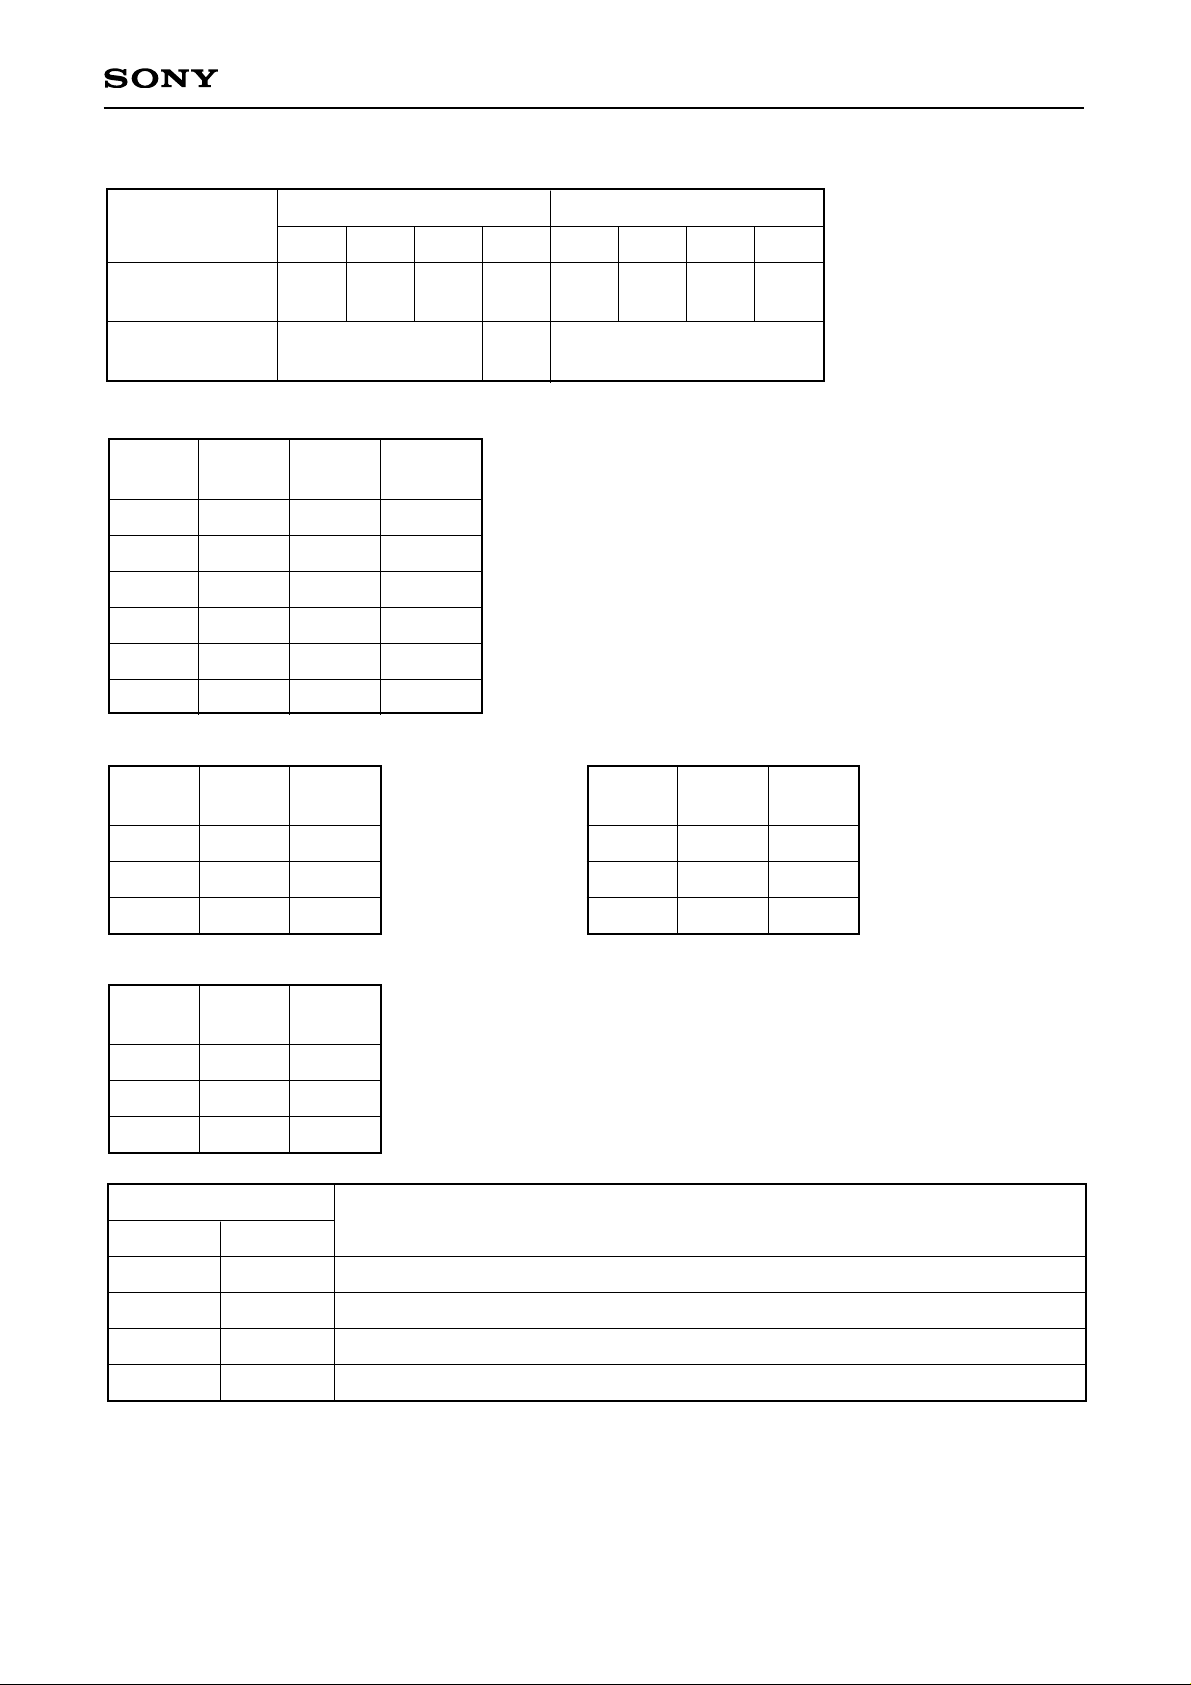
– 49 –
CXD2598Q
Spindle servo
coefficient setting
CLV CTRL ($DX)
Gain
MDP1
Gain
MDP0
Gain
MDS1
Gain
MDS0
Gain
CLVS
Gain
MDS1
0
0
0
0
1
1
Gain
MDS0
0
0
1
1
0
0
Gain
CLVS
0
1
0
1
0
1
GCLVS
–12dB
–6dB
–6dB
0dB
0dB
+6dB
Command
D3
Data 1
D2
D1
D0
Gain
DCLV0
Gain
DCLV1
PCC1
PCC0
D3
Data 2
D2
D1
D0
$CX commands
• CLVS mode gain setting: GCLVS
Gain
MDP1
0
0
1
Gain
MDP0
0
1
0
GMDP
–6dB
0dB
+6dB
Gain
DCLV1
0
0
1
Gain
DCLV0
0
1
0
GDCLV
0dB
+6dB
+12dB
Gain
MDS1
0
0
1
Gain
MDS0
0
1
0
GMDS
–6dB
0dB
+6dB
• CLVP mode gain setting: GMDP: GMDS
• DCLV overall gain setting: GDCLV
Command bit
PCC1 PCC0
Processing
The VPCO signal is output.
The VPCO pin output is high impedance.
The VPCO pin output is low.
The VPCO pin output is high.
0
0
1
1
0
1
0
1
• This command controls the VPCO pin signal.
The VPCO output can be controlled with this setting.
Page 50

– 50 –
CXD2598Q
Command
Data 3
D3
SFP3 SFP2 SFP1 SFP0 SRP3 SRP2 SRP1 SRP0
Spindle servo
coefficient setting
D2 D1 D0 D3 D2 D1 D0
Data 4
∗
See "§4-2. Frame Sync Protection" regarding frame sync protection.
Command bit
SRP3 to 0 Sets the frame sync backward protection times. The setting range is 1 to F (Hex).
Processing
Command bit
SFP3 to 0 Sets the frame sync forward protection times. The setting range is 1 to F (Hex).
Processing
• The CXD2598Q can serially output the 40 bits (10 BCD codes) of error monitor data selected by EDC0 to
EDC7 from the SQSO pin and monitor this data using a microcomputer.
The C1 and C2 error rate settings are sent one at a time by the $C commands by setting the SOCT0 and
SOCT1 commands of $8 to 1. Then, the data can be read out from the SQSO pin by sending 40 SQCK
pulses.
Command
Data 5
D3
EDC7 EDC6 EDC5 EDC4 EDC3 EDC2 EDC1 EDC0
Spindle servo
coefficient setting
D2 D1 D0 D3 D2 D1 D0
Data 6
Page 51

– 51 –
CXD2598Q
$DX commands
See "$CX commands".
Command bit
TB = 0
TB = 1
TP = 0
TP = 1
Bottom hold at a cycle of RFCK/32 in CLVS mode.
Bottom hold at a cycle of RFCK/16 in CLVS mode.
Peak hold at a cycle of RFCK/4 in CLVS mode.
Peak hold at a cycle of RFCK/2 in CLVS mode.
Description
Command
Data 1
CLV CTRL 0 TB TP
Gain
CLVS
D3 D2 D1 D0
Command bit
EDC7 = 0 EDC6
EDC5
EDC4
EDC3
EDC2
EDC1
EDC0
EDC7 = 1 EDC6
EDC5
EDC4
EDC3
EDC2
EDC1
EDC0
The [No C1 errors, pointer reset] count is output when 0.
The [One C1 error corrected, pointer reset] count is output when 0.
The [No C1 errors, pointer set] count is output when 0.
The [One C1 error corrected, pointer set] count is output when 0.
The [Two C1 errors corrected, pointer set] count is output when 0.
The [C1 correction impossible, pointer set] count is output when 0.
7350-frame count cycle mode∗1when 1.
73500-frame count cycle mode∗2when 0.
The [No C2 errors, pointer reset] count is output when 0.
The [One C2 error corrected, pointer reset] count is output when 0.
The [Two C2 errors corrected, pointer reset] count is output when 0.
The [Three C2 errors corrected, pointer reset] count is output when 0.
The [Four C2 errors corrected, pointer reset] count is output when 0.
The [C2 correction impossible, pointer copy] count is output when 0.
The [C2 correction impossible, pointer set] count is output when 0.
Processing
Error monitor commands
∗1
The value selected by C1 (EDC1 to EDC6) and C2 (EDC0 to 6) is added to C1 and C2 and output every
7350 frames.
∗2
The value selected by C1 (EDC1 to EDC6) and C2 (EDC0 to EDC6) is added to C1 and C2 and output
every 73500 frames.
Page 52

– 52 –
CXD2598Q
The rotational velocity R of the spindle can be expressed with the following equation.
R = × l
256 – n
32
∗
The above setting should be 0, 0 when not operating in the CAV-W mode.
Command bit
VPCTL1 VPCTL0
Processing
The setting of VP0 to VP7 is multiplied by 1.
The setting of VP0 to VP7 is multiplied by 2.
The setting of VP0 to VP7 is multiplied by 3.
The setting of VP0 to VP7 is multiplied by 4.
0
0
1
1
0
1
0
1
Command
Data 2
CLV CTRL VP7 VP6 VP5 VP4
D3 D2 D1 D0
Data 3
VP3 VP2 VP1 VP0
D3 D2 D1 D0
Data 4
VP
CTL1VPCTL0
0 0
D3 D2 D1 D0
Command bit
Processing
VP0 to 7 Sets the spindle rotational velocity.
R: Relative velocity at normal speed = 1
n: VP0 to VP7 setting value
1: Multiple set by VPCTL0, 1
Command bit
VP0 to 7 = F0(H)
VP0 to 7 = E0(H)
VP0 to 7 = C0(H)
Playback at half (normal) speed
to
Playback at normal (double) speed
to
Playback at (quadruple) speed
Description
Notes) 1. Values when crystal is 16.9344MHz and XTSL is low or when crystal is 33.8688MHz and XTSL is high.
2. Values in parentheses are for when DSPB is 1.
F0 E0
0.5
1
1.5
2
R – Relative velocity [multiple]
VP0 to VP7 setting value [HEX]
D0
2.5
3
C0
3.5
4
DSPB = 0
DSPB = 1
The settings in CAV-W mode are as follows.
… …
Page 53

– 53 –
CXD2598Q
Command bit
Processing
VPCTL1 to 0, VP7 to 0 Sets the pitch for the variable pitch mode.
The settings in variable pitch mode are as follows.
The pitch setting can be expressed with the following equation.
P = [%]
–n
10
P: Pitch setting value
n: VPCTL1 and VPCTL0, VP7 to VP0 setting value
(two's complement, VPCTL1 = sign bit)
The pitch setting range is from –48.7 to +51.2%.
The plus pitch setting should not exceed the playback speed given in the Recommended Operating Conditions.
An example of variable pitch mode commands is shown below.
$A4XXXXX (Setting to enable variable pitch mode.)
$ACXXXXX (Turns on variable pitch mode. The internal clock uses the VCO2 reference.)
$D60A00 (Sets the pitch to +1.0%.)
$D60000 (Sets the pitch to 0.0%.)
$A4XXXXX (Turns off variable pitch mode. The internal clock uses the crystal reference.)
VPCTL1
1
1
0
0
VPCTL0
0
1
0
1
VP7 to 0
00(H)
:
FF(H)
00(H)
:
FF(H)
00(H)
:
FF(H)
00(H)
:
E7(H)
Pitch setting value [%]
+51.2
to
+25.7
+25.6
to
+0.1
0.0
to
–25.5
–25.6
to
–48.7
Command setting
example
$D60080
:
$D6FF80
$D600C0
:
$D6FFC0
$D60000
:
$D6FF00
$D60040
:
$D6E740
Command bit
Page 54

– 54 –
CXD2598Q
$EX commands
Command
Data 1
SPD mode CM3 CM2 CM1 CM0
D3 D2 D1 D0
Data 2
EPWM SPDC ICAP SFSL
D3 D2 D1 D0
Data 3
VC2C HIFC LPWR VPON
D3 D2 D1 D0
Command bit
CM3 CM2 CM1
Description
Spindle stop mode.
∗1
Spindle forward rotation mode.
∗1
Spindle reverse rotation mode. Valid only when LPWR = 0
in any mode.
∗1
Rough servo mode. When the RF-PLL circuit isn't locked,
this mode is used to pull the disc rotations within the RFPLL capture range.
PLL servo mode.
Automatic CLVS/CLVP switching mode.
Used for normal playback.
0
1
1
1
1
0
0
0
0
1
1
1
0
0
1
1
1
1
CM0
0
0
0
0
1
0
Mode
STOP
KICK
BRAKE
CLVS
CLVP
CLVA
∗1
See Timing Charts 1-6 to 1-12.
When using the digital CLV servo, the sampling frequency of the internal digital filter switches simultaneously
with the CLVP/CLVS switching.
This means that the CLVS mode cut-off frequency fc is 70Hz when the TB command of $D = 0 or 140Hz when
the TB command of $D = 1.
Command bit
EPWM SPDC ICAP
Description
Crystal reference CLV servo.
Used for normal-speed
playback in CLV-W mode.
∗2
Spindle control with
VP0 to VP7.
Spindle control with the
external PWM.
VCO control
∗3
0
0
0
1
0
0
0
1
0
0
0
0
1
1
0
SFSL
0
0
0
0
0
VC2C
0
1
0
0
0
HIFC
0
1
1
1
1
LPWR
0
0
0
0
0
VPON
0
0
1
1
1
INV
VPCO
0
0
0
0
1
Mode
CLV-N
CLV-W
CAV-W
CAV-W
VCO-C
∗2
Figs. 3-1 and 3-2 show the control flow with the microcomputer software in CLV-W mode.
∗3
Fig. 3-3 shows the control flow with the microcomputer software in VCO-C mode.
Page 55

– 55 –
CXD2598Q
Mode
CLV-N
CLV-W
CAV-W
LPWR
0
0
1
0
1
Command
KICK
BRAKE
STOP
KICK
BRAKE
STOP
KICK
BRAKE
STOP
KICK
BRAKE
STOP
KICK
BRAKE
STOP
1-6 (a)
1-6 (b)
1-6 (c)
1-7 (a)
1-7 (b)
1-7 (c)
1-8 (a)
1-8 (b)
1-8 (c)
1-9 (a)
1-9 (b)
1-9 (c)
1-10 (a)
1-10 (b)
1-10 (c)
Timing chart
Mode
CLV-N
CLV-W
CAV-W
LPWR
0
0
1
0
1
0
1
1-11
1-12
1-13
1-14 (EPWM = 0)
1-15 (EPWM = 0)
1-16 (EPWM = 1)
1-17 (EPWM = 1)
Timing chart
Command
SPD mode
Data 4
• This sets the gain when controlling the spindle with VP0 to
VP7 in CAV-W mode.
Note) This setting is not valid when controlling the spindle with
the external PWM.
D3 D2 D1 D0
Gain
CAV1
Gain
CAV0
0
INV
VPCO
Gain
CAV1
0
0
1
1
Gain
CAV0
0
1
0
1
Gain
0dB
–6dB
–12dB
–18dB
See the previous page.
Page 56

– 56 –
CXD2598Q
Timing Chart 1-3
Rch 16bit C2 Pointer Lch 16bit C2 Pointer
If C2 Pointer = 1,
data is NG
C2 Pointer for upper 8bits C2 Pointer for lower 8bits
Rch C2 Pointer
C2 Pointer for upper 8bits C2 Pointer for lower 8bits
Lch C2 Pointer
LRCK
WDCK
CDROM = 0
C2PO
CDROM = 1
C2PO
48 bit slot
Page 57
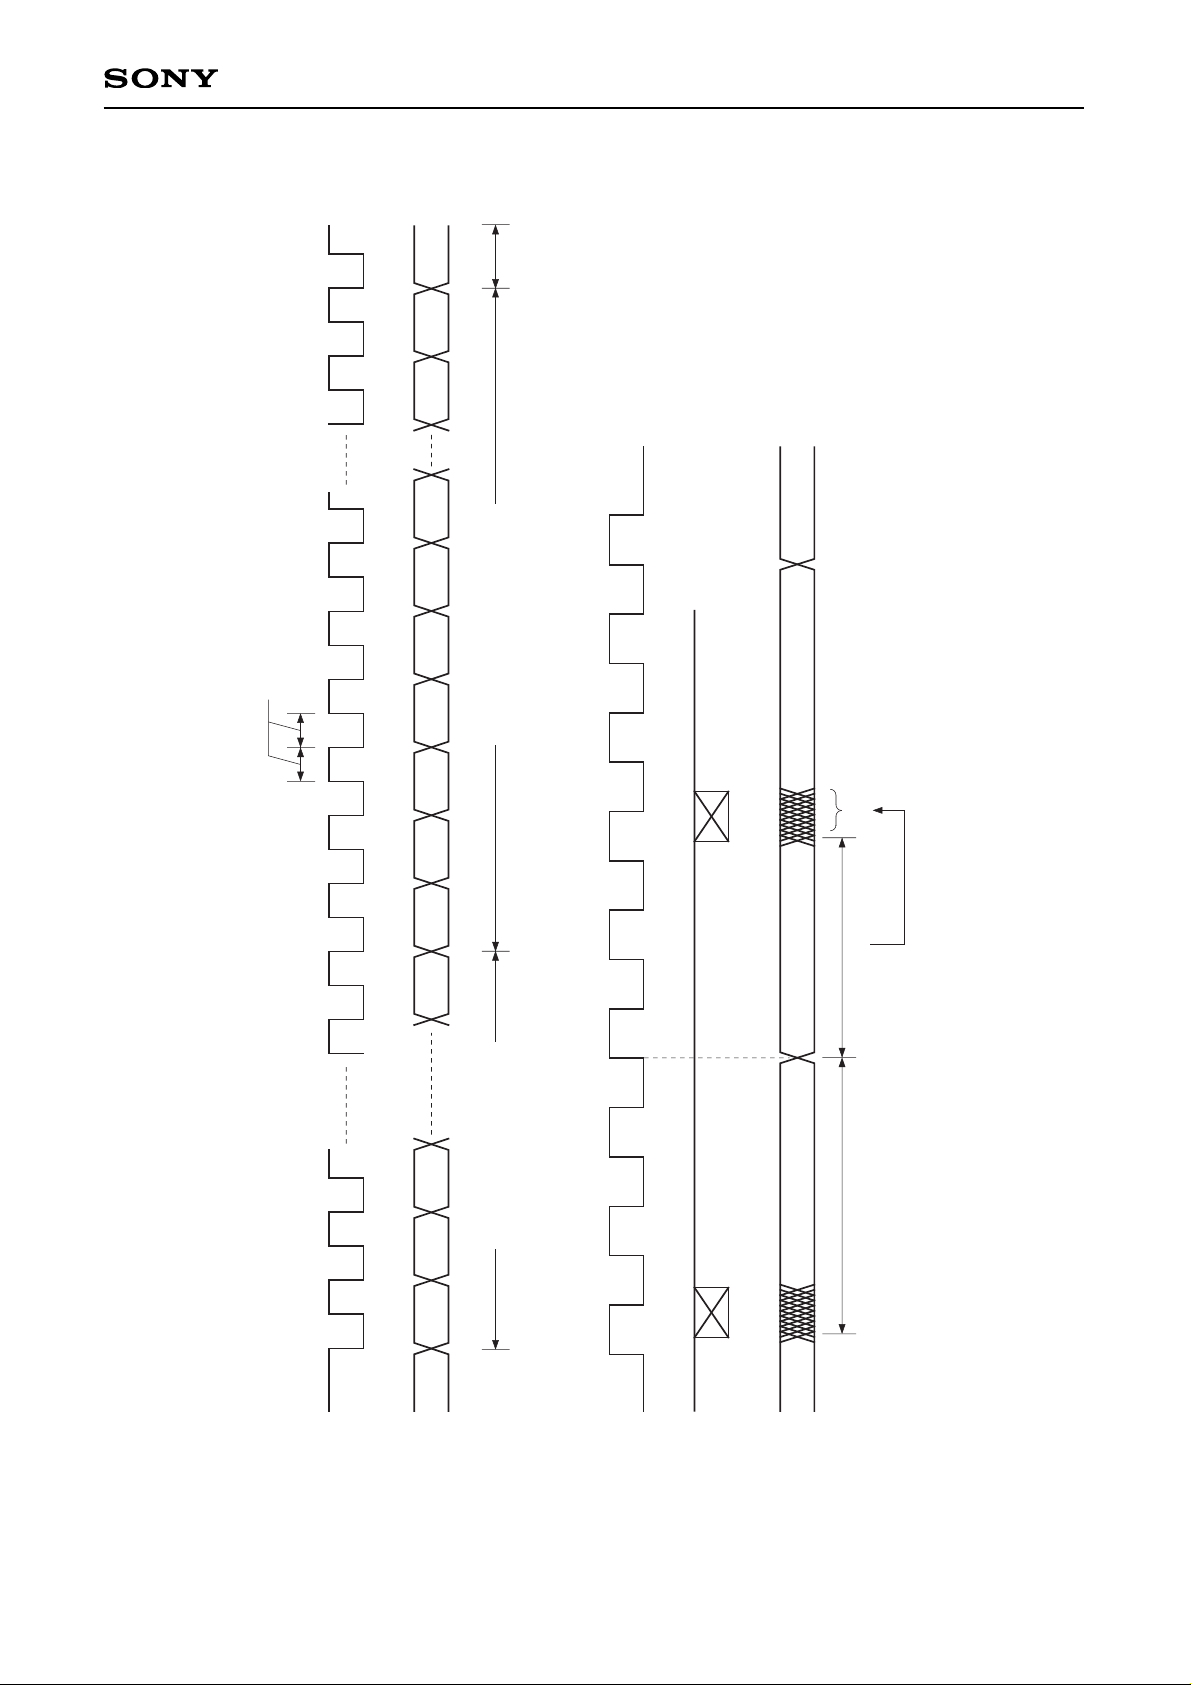
– 57 –
CXD2598Q
Timing Chart 1-4
Level Meter Timing
96 clock pulses
WFCK
1 2 3
96 clock pulses
CRCF CRCF
1 2 3
Peak data of this section
16 bit
R/LL/R
96 bit data
Hold section
1 2 3 80 81 96
CRCF
SQCK
D0 D1 D2 D3 D4 D5 D6 D13 D14 L/R
Peak data
L/R flag
Sub Q Data
See "Sub Code Interface"
15-bit peak-data
Absolute value display, LSB first
750ns to 120µs
SQCK
SQSO
SQSO
Page 58

– 58 –
CXD2598Q
Timing Chart 1-5
Measurement
Peak Meter Timing
96 clock pulses
CRCF
WFCK
1 2 3
Measurement Measurement
96 clock pulses
CRCF CRCF
1 2 3
SQCK
Page 59
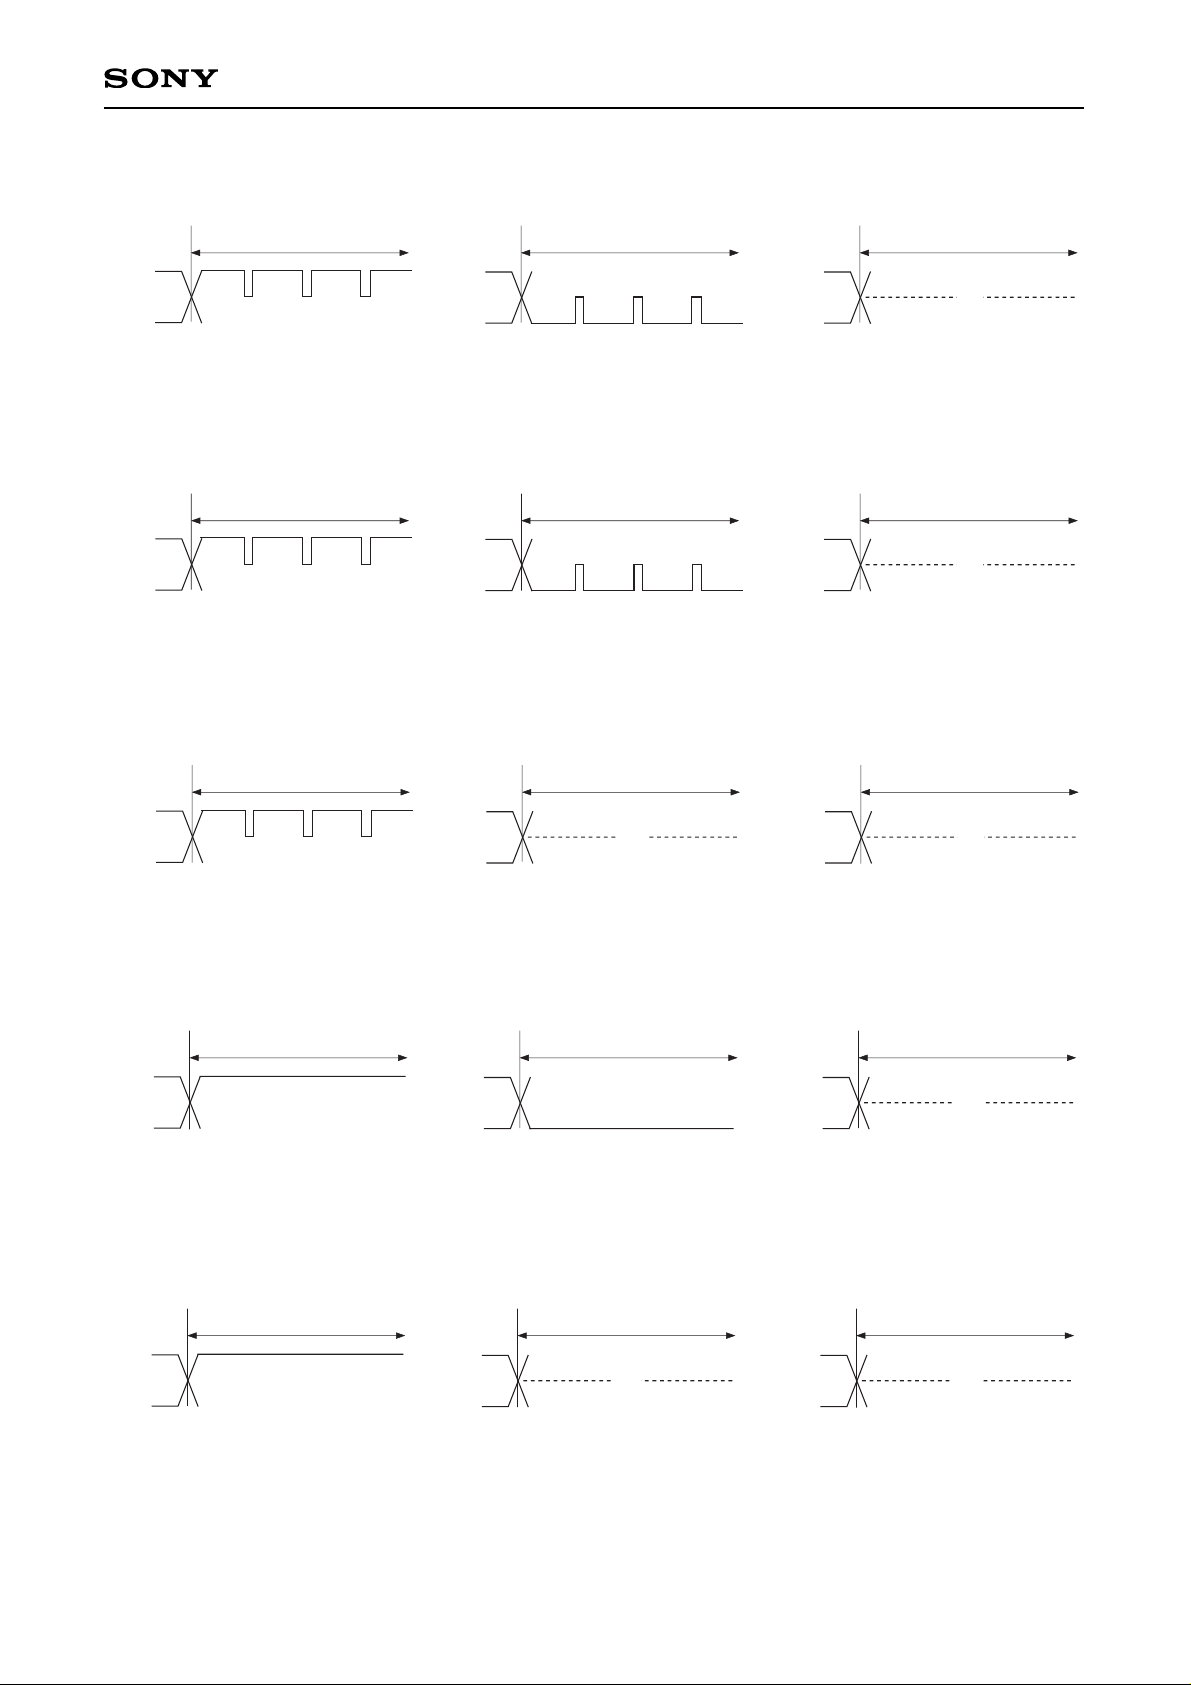
– 59 –
CXD2598Q
Timing Chart 1-6
CLV-N mode LPWR = 0
KICK
MDP
H
(a) KICK
BRAKE
MDP
(b) BRAKE
STOP
MDP
(c) STOP
Z
Z
L
Z
Timing Chart 1-7
CLV-W mode (when following the spindle rotational velocity) LPWR = 0
KICK
MDP
H
(a) KICK
BRAKE
MDP
(b) BRAKE
STOP
MDP
(c) STOP
Z
Z
L
Z
Timing Chart 1-8
CLV-W mode (when following the spindle rotational velocity) LPWR = 1
KICK
MDP
H
(a) KICK
BRAKE
MDP
(b) BRAKE
Z
STOP
MDP
(c) STOP
Z
Z
Timing Chart 1-9
CAV-W mode LPWR = 0
KICK
MDP
H
(a) KICK
BRAKE
MDP
(b) BRAKE
STOP
MDP
(c) STOP
Z
L
Timing Chart 1-10
CAV-W mode LPWR = 1
KICK
MDP
H
(a) KICK
BRAKE
MDP
(b) BRAKE
Z
STOP
MDP
(c) STOP
Z
Page 60

– 60 –
CXD2598Q
Timing Chart 1-14
CAV-W mode EPWM = LPWR = 0
MDP
Acceleration
Z
Deceleration
264kHz
3.8µs
Timing Chart 1-11
CLV-N mode LPWR = 0
MDP
Acceleration
Z
Deceleration
132kHz
7.6µs
n · 236 (ns) n = 0 to 31
Timing Chart 1-12
CLV-W mode LPWR = 0
MDP
Acceleration
Z
Deceleration
264kHz
3.8µs
Timing Chart 1-13
CLV-W mode LPWR = 1
MDP
Acceleration
Z
264kHz
3.8µs
The BRAKE pulse is masked when LPWR = 1.
Timing Chart 1-15
CAV-W mode EPWM = LPWR = 1
MDP
Acceleration
Z
264kHz
3.8µs
The BRAKE pulse is masked when LPWR = 1.
Page 61

– 61 –
CXD2598Q
Timing Chart 1-16
CAV-W mode EPWM = 1, LPWR = 0
PWMI
MDP
H
L
H
L
Acceleration
Deceleration
Timing Chart 1-17
CAV-W mode EPWM = LPWR = 1
PWMI
MDP
H
L
H
Z
Acceleration
The BRAKE pulse is masked when LPWR = 1.
Page 62

– 62 –
CXD2598Q
§2. Subcode Interface
There are two methods for reading out a subcode externally.
The 8-bit subcodes P to W can be read out from SBSO by inputting EXCK.
Sub-Q can be read out after checking CRC of the 80 bits in the subcode frame.
Sub-Q can be read out from the SQSO pin by inputting 80 clock pulses to the SQCK pin when SCOR comes
correctly and CRCF is high.
§2-1. P to W Subcode Readout
Data can be read out by inputting EXCK immediately after WFCK falls. (See Timing Chart 2-1.)
§2-2. 80-bit Sub-Q Readout
Fig. 2-2 shows the peripheral block of the 80-bit Sub-Q register.
• First, Sub-Q, regenerated at one bit per frame, is input to the 80-bit serial/parallel register and the CRC check
circuit.
• 96-bit Sub-Q is input, and if the CRC is OK, it is output to SQSO with CRCF = 1. In addition, 80 bits are
loaded into the parallel/serial register.
When SQSO goes high after SCOR is output, the CPU determines that new data (which passed the CRC
check) has been loaded.
• When the 80-bit data is loaded, the order of the MSB and LSB is inverted within each byte. As a result,
although the sequence of the bytes is the same, the bits within the bytes are now ordered LSB first.
• Once the 80-bit data load is confirmed, SQCK is input so that the data can be read.
The SQCK input is detected, and the retriggerable monostable multivibrator is reset while the input is low.
• The retriggerable monostable multivibrator has a time constant from 270 to 400µs. When the duration when
SQCK is high is less than this time constant, the monostable multivibrator is kept reset; during this interval,
the serial/parallel register is not loaded into the parallel/serial register.
• While the monostable multivibrator is being reset, data cannot be loaded in the peak detection parallel/serial
register or the 80-bit parallel/serial register.
In other words, while reading out with a clock cycle shorter than this time constant, the register will not be
rewritten by CRCOK and others.
• The previously mentioned peak detection register can be connected to the shift-in of the 80-bit parallel/serial
register.
For ring control 1, input and output are shorted during peak meter and level meter modes.
For ring control 2, input and output are shorted during peak meter mode.
This is because the register is reset with each readout in level meter mode, and to prevent readout
destruction in peak meter mode.
As a result, the 96-bit clock must be input in peak meter mode.
• The absolute time after peak is stored in the memory in peak meter mode as noted in "Description of peak
meter mode" on page 45. See Timing Chart 2-3.
• Clock input via the SQCK pin is necessary to perform these operations. The high and low intervals for SQCK
input should be between 750ns and 120µs.
Page 63

– 63 –
CXD2598Q
Timing Chart 2-1
Internal
PLL clock
4.3218 ± ∆MHz
WFCK
SCOR
EXCK
SBSO
750ns max
S0 · S1 Q R
WFCK
SCOR
EXCK
SBSO
S0•S1 Q R S T U V W
S0•S1
P1 Q R S T U V W P1 P2 P3
Same Same
Subcode P.Q.R.S.T.U.V.W Read Timing
Page 64

– 64 –
CXD2598Q
Block Diagram 2-2
888888888
Order
Inversion
16
Peak detection
LOAD CONTROL
Ring control 2
CRCF
Mix
Monostable
multivibrator
CRCC
ABS time load control
for peak value
16 bit P/S registerRing control 1
SO SI
SQSO
SQCKSHIFTSHIFT
SUBQ
LD
LD
LD
LD
LD
LD
LD
LD
SO
H G F E D C B A
A B C D E F G H
SI
80 bit P/S Register
80 bit S/P Register
(AFRAM) (ASEC) (AMIN) ADDRS CTRL
SIN
SUBQ
Page 65

– 65 –
CXD2598Q
Timing Chart 2-3
1
2
3
91 92 93 94
95 96 97
98
WFCK
SCOR
SQSO
SQCK
Monostable
Multivibrator
(Internal)
CRCF1
Determined by mode
CRCF2
80 or 96 Clock
Register load forbidder
270 to 400µs when SQCK = high.
750ns to 120µs
300ns max
CRCF
ADR0
ADR1
ADR2
ADR3
CTL0
CTL1
CTL2
CTL3
SQCK
SQSO
1
2
3
CRCF1
Page 66

– 66 –
CXD2598Q
Timing Chart 2-4
Example: $802000 latch
Set SQCK high during this interval.
Internal signal latch
PER0 PER1 PER2 PER3 PER4 PER5 PER6 PER7 C1F0 C1F1 C1F2 C2F0 C2F1 C2F2 FOK GFS LOCK EMPH
750ns or more
XLAT
SQCK
SQSO
ALOCK VF0 VF1 VF2 VF3 VF4 VF5 VF6 VF9VF7 VF8
Signal
PER0 to 7
FOK
GFS
LOCK
EMPH
ALOCK
VF0 to 9
RF jitter amount (used to adjust the focus bias). 8-bit binary data in PER0 = LSB, PER7 = MSB.
Focus OK.
High when the frame sync and the insertion protection timing match.
GFS is sampled at 460Hz; when GFS is high, a high signal is output. If GFS is low eight consecutive samples, a low signal is output.
High when the playback disc has emphasis.
GFS is sampled at 460Hz; when GFS is high eight consecutive samples, a high signal is output. If GFS is low eight consecutive
samples, a low signal is output.
Used in CAV-W mode. Results of measuring the disc rotational velocity. (See Timing Chart 2-5.) VF0 = LSB, VF9 = MSB.
Description
C1F2
0
0
0
0
1
1
1
1
0
0
1
1
0
0
1
1
0
1
0
1
0
1
0
1
No C1 errors; C1 pointer reset
One C1 error corrected; C1 pointer reset
—
—
No C1 errors; C1 pointer set
One C1 error corrected; C1 pointer set
Two C1 errors corrected; C1 pointer set
C1 correction impossible; C1 pointer set
C1F1 C1F0 Description
C2F2
0
0
0
0
1
1
1
1
0
0
1
1
0
0
1
1
0
1
0
1
0
1
0
1
No C2 errors; C2 pointer reset
One C2 error corrected; C2 pointer reset
Two C2 errors corrected; C2 pointer reset
Three C2 errors corrected;C2 pointer reset
Four C2 errors corrected; C2 pointer reset
—
C2 correction impossible; C1 pointer copy
C2 correction impossible; C2 pointer set
C2F1 C2F0 Description
Page 67

– 67 –
CXD2598Q
Timing Chart 2-5
Measurement interval (approximately 3.8µs)
Reference window
(132.2kHz)
Measurement pulse
(V16M/2)
Measurement counter
VF0 to 9
Load
m
The relative velocity R of the disc can be expressed with the following equation.
R = (R: Relative velocity, m: Measurement results)
VF0 to VF9 is the result obtained by counting V16M/2 pulses while the reference signal (132.2kHz) generated
from XTAL (XTAI, XTAO) (384Fs) is high. This count is 31 when the disc is rotating at normal speed and 63
when it is rotating at double speed (when DSPB is low).
m + 1
32
Page 68

– 68 –
CXD2598Q
Timing Chart 2-6
18 17C1 MSB 19 16 15 14 13 12 11 10 9 8 7 6 5 4 3 2 1 0 19 18 17 16 15 14 13 12 11 10 9 8 7 6 5 4 3 2 1 0
0537005370
C1 error rate C2 error rate
XLAT
SQCK
SQSO
Page 69

– 69 –
CXD2598Q
§3. Description of Modes
This LSI has three basic operating modes using a combination of spindle control and the PLL. The operations
for each mode are described below.
§3-1. CLV-N Mode
This mode is compatible with the CXD2510Q, and operation is the same as for conventional control. The PLL
capture range is ±150kHz.
§3-2. CLV-W Mode
This is the wide capture range mode. This mode allows the conventional PLL to follow the rotational velocity of
the disc. This rotational following control has two types: using the built-in VCO2 or providing an external VCO.
The spindle is the same CLV servo as for the conventional series. Operation using the built-in VCO2 is
described below. (When using an external VCO, input the signal from the VPCO pin to the low-pass filter, use
the output from the low-pass filter as the control voltage for the external VCO, and input the oscillation output
from the VCO to the V16M pin.)
When starting to rotate the disc and/or speeding up to the lock range from the condition where the disc is
stopped, CAV-W mode should be used. Specifically, first send $E665X to set CAV-W mode and kick the disc,
then send $E60CX to set CLV-W mode if ALOCK is high. The microcomputer monitors the serial data output,
and must return the operation to the speed adjusting state (CAV-W mode) when ALOCK becomes low. The
control flow according to the microcomputer software is shown in Fig. 3-2.
In CLV-W mode (normal), low power consumption is achieved by setting LPWR to high. Control was formerly
performed by applying acceleration and deceleration pulses to the spindle motor. However, when LPWR is set
to high, deceleration pulses are not output, thereby achieving low power consumption mode.
Note) The capture range for this mode is theoretically up to the signal processing limit.
§3-3. CAV-W Mode
This is CAV mode. In this mode, the external clock is fixed and it is possible to control the spindle to the
desired rotational velocity. The rotational velocity is determined by the VP0 to VP7 setting values or the
external PWM. When controlling the spindle with VP0 to VP7, setting CAV-W mode with the $E665X command
and controlling VP0 to VP7 with the $DX commands allows the rotational velocity to be varied from low speed
to quadruple speed. (See "$DX commands".) When controlling the spindle with the external PWM, the PWMI
pin is binary input which becomes KICK during high intervals and BRAKE during low intervals.
The microcomputer can know the rotational velocity using V16M. The reference for the velocity measurement
is a signal of 132.3kHz obtained by 1/128-frequency dividing XTAL (XTAI, XTAO) (384Fs). The velocity is
obtained by counting half of the V16M pulses while the reference is high, and the result is output from the new
CPU interface as 10 bits (VF0 to VP9). These measurement results are 31 when the disc is rotating at normal
speed or 127 when it is rotating at quadruple speed. These values match those of the 256 - n for control with
VP0 to VP7. (See Table 2-5 and Fig. 2-6.)
In CAV-W mode, the spindle is set to the desired rotational velocity and the operation speed for the entire
system follows this rotational velocity. Therefore, the cycles for the Fs system clock, PCM data and all other
output signals from this LSI change according to the rotational velocity of the disc.
Note) The capture range for CAV-W mode is theoretically up to the signal processing limit.
Note) Set FLFC to 1 for this mode.
Page 70
– 70 –
CXD2598Q
§3-4. VCO-C Mode
This is VCO control mode. In this mode, the V16M oscillation frequency can be controlled by setting $D
commands VP0 to VP7 commands and VPCTL0, 1. The V16M oscillation frequency can be expressed by the
following equation.
V16M =
The VCO1 oscillation frequency is determined by V16M. The VCO1 frequency can be expressed by the
following equation.
• When DSPB = 0
VCO1 = V16M ×
• When DSPB = 1
VCO1 = V16M ×
49
24
1(256 – n)
32
n: VP0 to VP7 setting value
1: VPCTL0, 1 setting value
49
16
Page 71

– 71 –
CXD2598Q
CAV-W
CLVS
CLV-W
CLVP
Rotational velocity
Target speed
Operation mode
Spindle mode
Time
KICK
LOCK
ALOCK
Fig. 3-1. Disc Stop to Regular Playback in CLV-W Mode
CLV-W Mode
NO
YES
KICK $E8000
Mute OFF $A00XXXX
ALOCK = H ?
NO
YES
ALOCK = L ?
CLV-W MODE
START
CAV-W $E665X
(CLVA)
CLV-W $E60CX
(CLVA)
(WFCK PLL)
Fig. 3-2. CLV-W Mode Flow Chart
Page 72

– 72 –
CXD2598Q
VCO-C Mode
R?
(How many minutes
of absolute time?)
Access START
Transfer
$E00510
n?
(Caluculate n)
Transfer
$DX XX
Track Jump
Subroutine
Transfer
$E66500
Access END
What is the playback speed when access ends?
Caluculate VP0 to VP7.
Switch to VCO control mode
EPWM = SPDC = ICAP = SFSL = VC2C = LPWR = 0
HIFC = VPON = 1
Transfer VP0 to VP7.
( corresponds to VP0 to VP7.)
Switch to normal-speed playback mode.
EPWM = SFSL = VC2C = LPWR = 0
SPDC = ICAP = HIFC = VPON = 1
Fig. 3-3. Access Flow Chart Using VCO Control
Page 73

– 73 –
CXD2598Q
§4. Description of other functions
§4-1. Channel Clock Recovery by Digital PLL Circuit
• The channel clock is necessary for demodulating the EFM signal regenerated by the optical system.
Assuming T as the channel clock cycle, the EFM signal is modulated in an integer multiple of T from 3T to
11T. In order to read the information in the EFM signal, this integer value must be read correctly. As a result,
T, that is the channel clock, is necessary.
In an actual player, the PLL is necessary to recover the channel clock because the fluctuation in the spindle
rotation alters the width of the EFM signal pulses.
The block diagram of this PLL is shown in Fig. 4-1.
The CXD2598Q has a built-in three-stage PLL.
• The first-stage PLL is for the wide-band PLL. When the internal VCO2 is used, an external LPF is necessary;
when not using the internal VCO2, external LPF and VCO are required.
The output of this first-stage PLL is used as a reference for all clocks within the LSI.
• The second-stage PLL generates the high-frequency clock needed by the third-stage digital PLL.
• The third-stage PLL is a digital PLL that recovers the actual channel clock.
• The digital PLL in CLV-N mode has a secondary loop, and is controlled by the primary loop (phase) and the
secondary loop (frequency). When FLFC = 1, the secondary loop can be turned off. High frequency
components such as 3T and 4T may contain deviations. In such a case, turning off the secondary loop yields
better playability. However, in this case the capture range becomes ±50kHz.
• A new digital PLL has been provided for CLV-W mode to follow the rotational velocity of the disc in addition
to the conventional secondary loop.
Page 74

– 74 –
CXD2598Q
Block Diagram 4-1
XTSL
1/2 1/32
1/n
1/2
Microcomputer
control
n = 1 to 256
(VP7 to 0)
1/K
(KSL1, 0)
CLV-W
CAV-W
Spindle rotation information
CLV-N
CLV-W
CAV-W
/CLV-N
Phase comparator
Selector
LPF
2/1 MUX
VPON
1/M
1/N
VCOSEL2
VCO2
Phase comparator
VCO1
VCOSEL1
1/K
(KSL3, 2)
Digital PLL
RFPLL
VPCO
VCTL
V16M
PCO
FILI
FILO
CLTV
XTAI
Clock input
1/l
l = 1, 2, 3, 4
(VPCTL0, 1)
Page 75
– 75 –
CXD2598Q
§4-2. Frame sync protection
• In normal speed playback, a frame sync is recorded approximately every 136µs (7.35kHz). This signal is
used as a reference to recognize the data within a frame. Conversely, if the frame sync cannot be
recognized, the data is processed as error data because the data cannot be recognized. As a result,
recognizing the frame sync properly is extremely important for improving playability.
• In the CXD2598Q, window protection and forward protection/backward protection have been adopted for
frame sync protection. These functions achieve very powerful frame sync protection. There are two window
widths; one for cases where a rotational disturbance affects the player and the other for cases where there is
no rotational disturbance (WSEL = 0/1). In addition, the forward protection counter is set to 13∗, and the
backward protection counter to 3∗. Concretely, when the disc is being played back normally and then the
frame sync cannot be detected due to scratches etc., a maximum of 13 frames are inserted. If the frame sync
cannot be detected for 13 frames or more, the window opens to resynchronize the frame sync.
In addition, immediately after the window opens and the resynchronization is executed, if a proper frame
sync cannot be detected within 3 frames, the window opens immediately.
∗
Default values. These values can be set as desired by the SFP3 to SFP0 and SRP3 to SRP0 commands of $C.
§4-3. Error Correction
• In the CD format, one 8-bit data contains two error correction codes, C1 and C2. For C1 correction, the code
is created with 28-byte information and 4-byte C1 parity.
For C2 correction, the code is created with 24-byte information and 4-byte parity.
Both C1 and C2 are Reed-Solomon codes with a minimum distance of 5.
• The CXD2598Q uses refined super strategy to achieve double correction for C1 and quadruple correction for
C2.
• In addition, to prevent C2 miscorrection, a C1 pointer is attached to data after C1 correction according to the
C1 error status during C1 error correction, the playback status of the EFM signal, and the operating status of
the player.
• The correction status can be monitored externally.
See Table 4-2.
• When the C2 pointer is high, the data in question was uncorrectable. Either the pre-value was held or an
average value interpolation was made for the data.
MNT3
0
0
0
0
0
0
0
0
1
1
1
1
1
1
1
1
0
0
0
0
1
1
1
1
0
0
0
0
1
1
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
0
1
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
0
1
No C1 errors; C1 pointer reset
One C1 error corrected; C1 pointer reset
—
—
No C1 errors; C1 pointer set
One C1 error corrected; C1 pointer set
Two C1 errors corrected; C1 pointer set
C1 correction impossible; C1 pointer set
No C2 errors; C2 pointer reset
One C2 error corrected; C2 pointer reset
Two C2 errors corrected; C2 pointer reset
Three C2 errors corrected; C2 pointer reset
Four C2 errors corrected; C2 pointer reset
—
C2 correction impossible; C1 pointer copy
C2 correction impossible; C2 pointer set
MNT2 MNT1 MNT0 Description
Table 4-2.
Page 76

– 76 –
CXD2598Q
Timing Chart 4-3
Normal-speed PB
400 to 500ns
RFCK
MNT3
MNT1
MNT0
t = Dependent on error
condition
C1 correction C2 correction
Strobe
Strobe
MNT2
§4-4. DA Interface
• The DA interface supports the 48-bit slot interface.
48-bit slot interface
This interface includes 48 cycles of the bit clock within one LRCK cycle, and is MSB first. When LRCK is
high, the data is for the left channel.
Page 77

– 77 –
CXD2598Q
Timing Chart 4-4
LRCK
(44.1K)
BCK
(2.12M)
WDCK
PCMD
LRCK
(88.2K)
BCK
(4.23M)
WDCK
PCMD
48-bit slot Normal-Speed Playback
1
24
R0
Lch MSB (15)
L14 L13 L12 L11 L10 L9 L8 L7 L6 L5 L4 L3 L2 L1 L0 Rch MSB
Lch MSB (15)
24
Rch MSB
2 3 4 5 6 7 8 9 10 11 12
48-bit slot Double-Speed Playback
1 2
L0
R0
Page 78

– 78 –
CXD2598Q
§4-5. Digital Out
There are three Digital Out: the type 1 format for broadcasting stations, the type 2 form 1 format for home use,
and the type 2 form 2 format for the manufacture of software.
The CXD2598Q supports type 2 form 1.
The CXD2598Q also supports two Digital Out generation methods: generation from the PCM data read out
from the disc, and generation from the DA interface input (PCMDI, LRCKI, BCKI).
§4-5-1. Digital Out from PCM Data
Digital Out is generated from the PCM data read out from the disc.
The channel status clock accuracy is automatically set to level II when using the crystal clock and to level III in
CAV-W mode or variable pitch mode. In addition, Sub-Q data which are matched twice in succession after a
CRC check are input to the first four bits (bits 0 to 3).
DOUT is output when the crystal is 34MHz, XTSL is high and DSPB is set to 1 in CLV-N or CLV-W mode.
Therefore, set the MD2 pin to 0 and turn DOUT off.
0
0 0 0 0 0 0 0 0 0 0 0 0 0 0 /1 0 0
0
ID0
ID1
COPY
Emph
0 0 0 0 1 0 0 0 0 0 0 0
From sub Q
0
16
32
48
176
Sub Q control bits that matched twice in succession with CRCOK
Digital Out C bit
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15
VPON or VARION: 1 Crystal: 0
bits 0 to 3
bit 29
Table 4-5-1.
Page 79

– 79 –
CXD2598Q
§4-5-2. Digital Out from DA Interface Input
Digital Out is generated from the DA interface input.
Validity Flag, User Data
The Validity Flag and User Data are fixed to 0.
Channel Status Data
Bits 0, 6 and 7 of the Channel Status Data are fixed to 0. In addition, the following items can be set by bits 1, 2,
3 and 8.
a) Digital data/audio data
b) Digital copy allowed/prohibited
c) Pre-emphasis on/off
d) Category code (2 types)
0
0 0 0 0 0 0 0 0 0 0 0 0 0 0 0 0
0
0
A/D
SEL
COPY
En
EMPH
D
0 0 0 0
CAT
b8
0 0 0 0 0 0 0
0
16
32
48
176
Digital Out C bit
1 2 3 4 5 6 7 8 9 10 11 12 13 14 15
Table 4-5-2.
Note) When using this generation method, turn DOUT off by first setting the MD pin to 0 and then setting the
DOUT EN command of $34A to 0.
Page 80

– 80 –
CXD2598Q
Digital audio data input
The digital audio data input signal is input from the DAC input pins PCMDI, LRCKI and BCKI. The input format
supports the 48-bit slot, MSB first.
Mute function
The audio data portion of the Digital Out output can be set to all zero without altering the Channel Status Data
by setting command bit DOUT_DMUT to 1.
I/O sync circuit
The DAC is automatically synchronized to the input LRCK during normal operation, but synchronization may
not be possible when the input data contains a large amount of jitter or during power-on, etc. In such a case,
internal operation must be forcibly resynchronized by setting the DOUT WOD command of $34A to 1. Forced
synchronization is also necessary when the operating frequency is switched such as when switching between
CLV and CAV. When performing resynchronization, be sure to first return DOUT WOD to 0 and then set to 1.
∗
Resynchronization clears the internal frame counter, so the count starts over from frame 0 after the
resynchronization processing. The resynchronization circuit can be disabled by setting the WINEN command
of $34A to 0 so that resynchronization processing is not performed automatically or to perform
resynchronization processing at the user's discretion.
DOUT circuit clock system
The DOUT block master clock is set using the clock control command MCSL ($A) used by the DAC block.
Therefore, set MCSL = 1 when using 768fs, and MCSL = 0 when using 384fs.
Page 81

– 81 –
CXD2598Q
LRCK
BCKI
PCMDI
48-bit slot
1
24
R0
Lch MSB (15)
L14 L13 L12 L11 L10 L9 L8 L7 L6 L5 L4 L3 L2 L1 L0 Rch MSB
2 3 4 5 6 7 8 9 10 11 12
DOUT Block Input Timing Chart
Page 82

– 82 –
CXD2598Q
§4-6. Servo Auto Sequence
This function performs a series of controls, including auto focus and track jumps. When the auto sequence
command is received from the CPU, auto focus, 1-track jump, 2N-track jump, fine search and M-track move
are executed automatically.
The servo block operates according to the built-in program during the auto sequence execution (when XBUSY
= low), so that commands from the CPU, that is $0, 1, 2 and 3 commands, are not accepted. ($4 to E
commands are accepted.)
In addition, when using the auto sequence, turn the A.SEQ ON-OFF of register 9 on.
When CLOK goes from low to high while XBUSY is low, XBUSY does not become high for a maximum of
100µs after that point. This is to prevent the transfer of erroneous data to the servo when XBUSY changes
from low to high by the monostable multivibrator, which is reset by CLOK being low (when XBUSY is low).
In addition, a MAX timer is built into this LSI as a countermeasure against abnormal operation due to external
disturbances, etc. When the auto sequence command is sent from the CPU, this command assumes a $4XY
format, in which X specifies the command and Y sets the MAX timer value and timer range. If the executed
auto sequence command does not terminate within the set timer value, the auto sequence is interrupted (like
$40). See "§1 $4X commands" concerning the timer value and range. Also, the MAX timer is invalidated by
inputting $4X0.
Although this command is explained in the format of $4X in the following command descriptions, the timer
value and timer range are actually sent together from the CPU.
(a) Auto focus ($47)
Focus search-up is performed, FOK and FZC are checked, and the focus servo is turned on.
If $47 is received from the CPU, the focus servo is turned on according to Fig. 4-6. The auto focus starts with
focus search-up, and note that the pickup should be lowered beforehand (focus search-down). In addition,
blind E of register 5 is used to eliminate FZC chattering. Concretely, the focus servo is turned on at the falling
edge of FZC after FZC has been continuously high for a longer time than E.
(b) Track jump
1, 10 and 2N-track jumps are performed respectively. Always use this when the focus, tracking, and sled
servos are on. Note that tracking gain-up and braking-on ($17) should be sent beforehand because they are
not involved in this sequence.
• 1-track jump
When $48 ($49 for REV) is received from the CPU, a FWD (REV) 1-track jump is performed in accordance
with Fig. 4-7. Set blind A and brake B with register 5.
• 10-track jump
When $4A ($4B for REV) is received from the CPU, a FWD (REV) 10-track jump is performed an
accordance with Fig. 4-8. The principal difference from the 1-track jump is to kick the sled. In addition, after
kicking the actuator, when 5 tracks have been counted through COUT, the brake is applied to the actuator.
Then, when the actuator speed is found to have slowed up enough (determined by the COUT cycle
becoming longer than the overflow C set with register 5), the tracking and sled servos are turned on.
Page 83

– 83 –
CXD2598Q
• 2N-track jump
When $4C ($4D for REV) is received from the CPU, a FWD (REV) 2N-track jump is performed an
accordance with Fig. 4-9. The track jump count N is set with register 7. Although N can be set to 2
16
tracks,
note that the setting is actually limited by the actuator. COUT is used for counting the number of jumps
when N is less than 16, and MIRR is used when N is 16 or more.
Although the 2N-track jump basically follows the same sequence as the 10-track jump, the one difference is
that after the tracking servo is turned on, the sled continues to move only for "D", set with register 6.
• Fine search
When $44 ($45 for REV) is received from the CPU, a FWD (REV) fine search (N-track jump) is performed
in accordance with Fig. 4-10. The differences from a 2N-track jump are that a higher precision is achieved
by controlling the traverse speed, and a longer distance jump is made possible by controlling the sled. The
track jump count N is set with register 7. N can be set to 216tracks. After kicking the actuator and sled, the
traverse speed is controlled based on the overflow G. Set kick D and F with register 6 and overflow G with
register 5. Also, sled speed control during traverse can be turned off by causing COMP to fall. Set the
number of tracks during which COMP falls with register B. After N tracks have been counted through
COUT, the brake is applied to the actuator and sled. (This is performed by turning on the tracking servo for
the actuator, and by kicking the sled in the opposite direction during the time for kick D set with register 6.)
Then, the tracking and sled servos are turned on.
Set overflow G to the speed required to slow up just before the track jump terminates. (The speed should
be such that it will come on-track when the tracking servo turns on at the termination of the track jump.) For
example, set the target track count N - a in the traverse monitor counter which is set with register B, and
COMP will be monitored. When the falling edge of this COMP is detected, overflow G can be reset.
• M-track move
When $4E ($4F for REV) is received from the CPU, a FWD (REV) M-track move is performed in
accordance with Fig. 4-11. M can be set to 216tracks. Like the 2N-track jump, COUT is used for counting
the number of moves when M is less than 16, and MIRR is used when M is 16 or more. The M-track move
is executed only by moving the sled, and is therefore suited for moving across several thousand to several
ten-thousand tracks. In addition, the track and sled servos are turned off after M tracks have been counted
through COUT or MIRR unlike for the other jumps. Transfer $25 from the microcomputer after the actuator
has stabilized.
Page 84

– 84 –
CXD2598Q
Auto focus
Focus search up
FOK = H
NO
YES
FZC = H
NO
YES
FZC = L
NO
YES
END
Focus servo ON
Check whether FZC is continuosly
high for the period of time E set
with register 5.
Fig. 4-6-(a). Auto Focus Flow Chart
XLAT
$47 Latch
$03
Blind E
$08
FOK
FZC
BUSY
Command for
DSSP
Fig. 4-6-(b). Auto Focus Timing Chart
Page 85

– 85 –
CXD2598Q
1 Track
NO
YES
END
Track FWD kick
sled servo OFF
WAIT
(Blind A)
COUT =
Track REV
kick
WAIT
(Brake B)
Track, sled
servo ON
(FWD kick for REV jump)
(REV kick for REV jump)
Fig. 4-7-(a). 1-Track Jump Flow Chart
XLAT
COUT
BUSY
Command for
DSSP
$48 (REV = $49) Latch
$28 ($2C)
Blind A
Brake B
$2C ($28)
$25
Fig. 4-7-(b). 1-Track Jump Timing Chart
Page 86

– 86 –
CXD2598Q
10 Track
NO
YES
END
Track, sled
FWD kick
WAIT
(Blind A)
COUT = 5 ?
Track, REV
kick
Track, sled
servo ON
Checks whether the COUT cycle
is longer than overflow C.
(Counts COUT × 5)
NO
YES
C = Overflow ?
Fig. 4-8-(a). 10-Track Jump Flow Chart
COUT
$4A (REV = $4B) Latch
Blind A
$2A ($2F)
COUT 5 count
$2E ($2B)
Overflow C
$25
XLAT
BUSY
Command for
DSSP
Fig. 4-8-(b). 10-Track Jump Timing Chart
Page 87

– 87 –
CXD2598Q
2N Track
NO
YES
END
Track, sled
FWD kick
WAIT
(Blind A)
COUT (MIRR) = N
Track REV
kick
Track servo
ON
NO
YES
C = Overflow
WAIT
(Kick D)
Sled servo
ON
Counts COUT for the first 16 times
and MIRR for more times.
Fig. 4-9-(a). 2N-Track Jump Flow Chart
XLAT
Blind A
$2A ($2F)
COUT (MIRR)
N count
$2E ($2B)
Overflow C
Kick D
$26 ($27)
$25
$4C (REV = $4D) Latch
COUT
(MIRR)
BUSY
Command for
DSSP
Fig. 4-9-(b). 2N-Track Jump Timing Chart
Page 88

– 88 –
CXD2598Q
Track Servo ON
Sled FWD Kick
Fine Search
WAIT
(Kick D)
Track Sled
FWD Kick
WAIT
(Kick F)
Traverse
Speed Ctrl
(Overflow G)
COUT = N ?
Track Servo ON
Sled REV Kick
WAIT
(Kick D)
Track Sled
Servo ON
END
YES
NO
Fig. 4-10-(a). Fine Search Flow Chart
Traverse Speed Control (Overflow G)
&
COUT N count
Kick FKick D
$26 ($27)
$2A ($2F)
$27 ($26)
$25
$44 (REV = $45) latch
XLAT
COUT
Kick D
BUSY
Command for
DSSP
Fig. 4-10-(b). Fine Search Timing Chart
Page 89
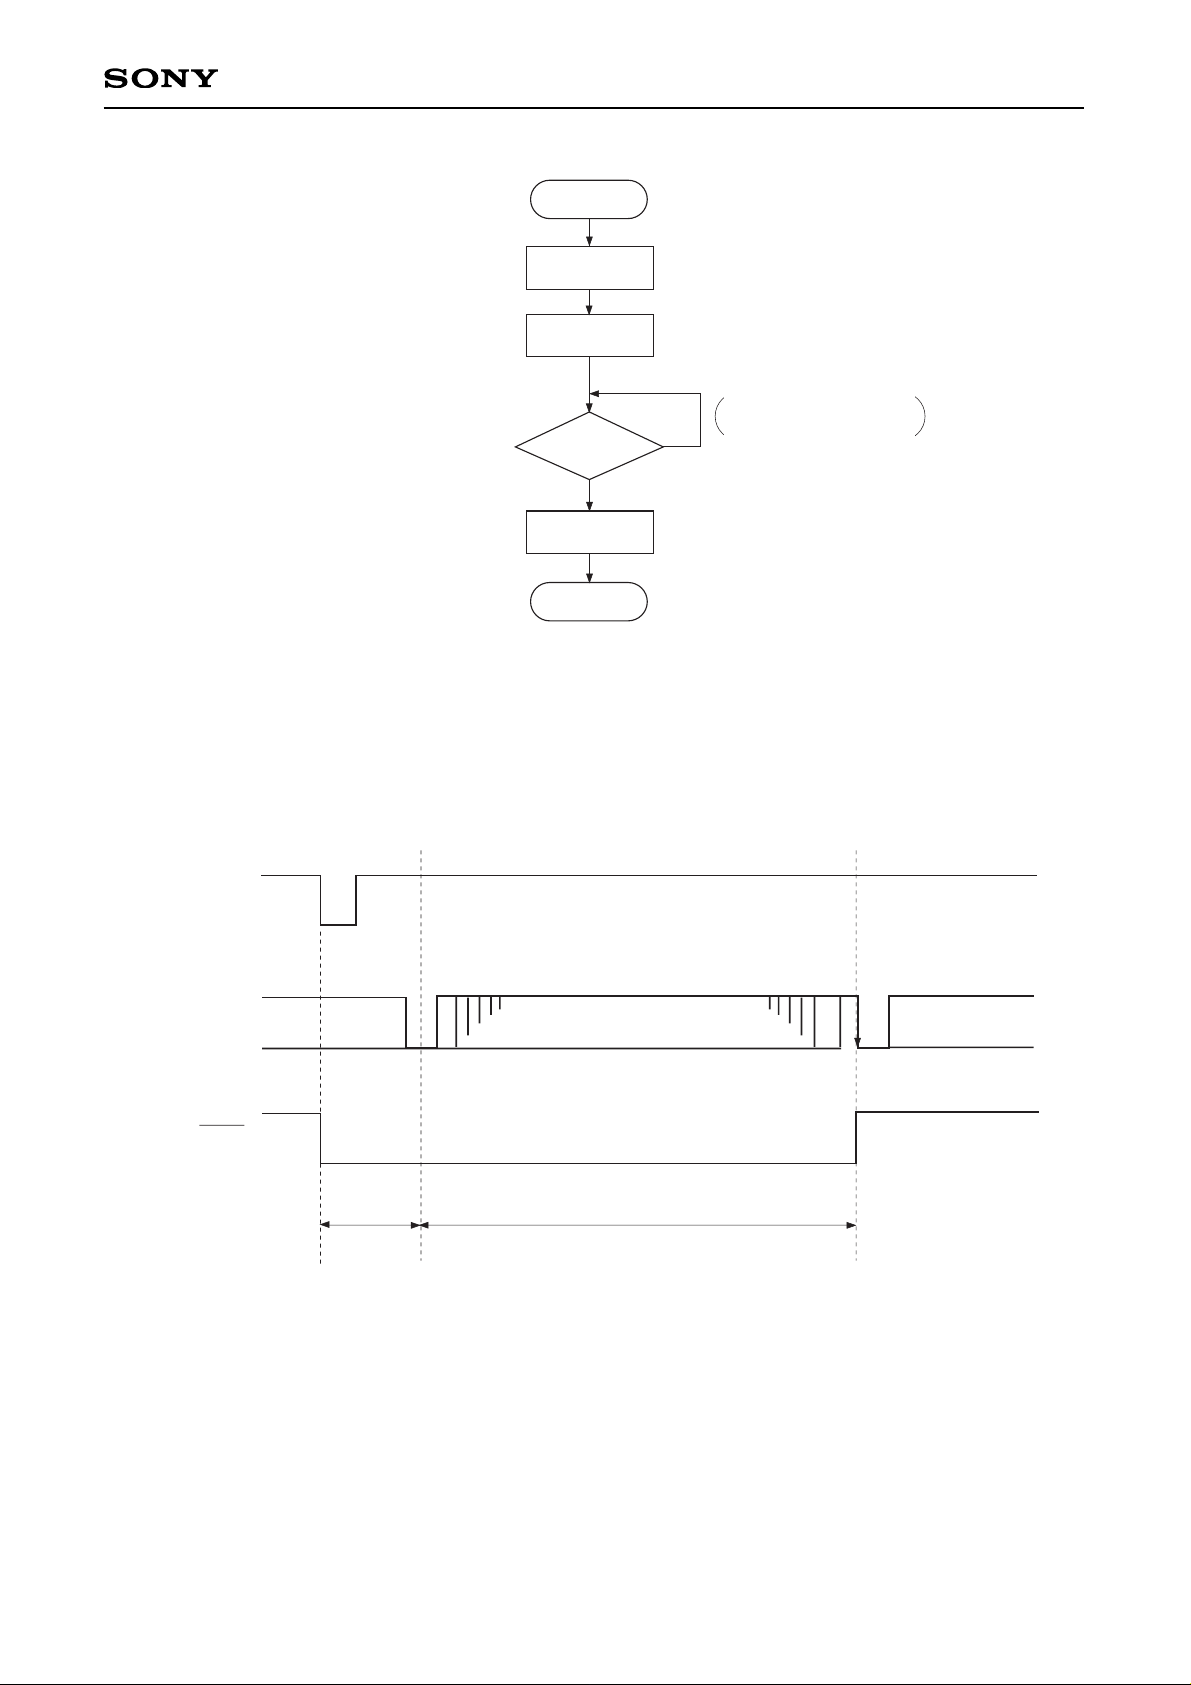
– 89 –
CXD2598Q
M Track Move
NO
YES
END
Track Servo OFF
Sled FWD Kick
WAIT
(Blind A)
COUT (MIRR) = M
Track, Sled
Servo OFF
Counts COUT for M < 16.
Counts MIRR for M ≥ 16.
Fig. 4-11-(a). M-Track Move Flow Chart
XLAT
Blind A
$22 ($23)
COUT (MIRR)
M count
$20
$4E (REV = $4F) Latch
COUT
(MIRR)
BUSY
Command for
DSSP
Fig. 4-11-(b). M-Track Move Timing Chart
Page 90

– 90 –
CXD2598Q
§4-7. Digital CLV
Fig. 4-12 shows the block diagram. Digital CLV outputs MDS error and MDP error signals with PWM, with the
sampling frequency increased up to 130kHz during normal-speed playback in CLVS, CLVP and other modes.
In addition, the digital spindle servo gain is variable.
MDP
Digital CLV
CLVS U/D
MDS Error
MDP Error
CLV P/S
Measure
Measure
2/1 MUX
Over Sampling
Filter-1
Gain
MDS
1/2
Mux
CLV P/S
Over Sampling
Filter-2
Noise Shape
Modulation
KICK, BRAKE, STOP
Mode Select
+
Gain
DCLV
Gain
MDP
LPWR
PWMI
Fig. 4-12. Block Diagram
CLVS U/D: Up/down signal from CLVS servo
MDS error: Frequency error for CLVP servo
MDP error: Phase error for CLVP servo
PWMI: Spindle drive signal from microcomputer for CAV servo
Page 91

– 91 –
CXD2598Q
§4-8. CD-DSP Block Playback Speed
In the CXD2598Q, the following playback modes can be selected through different combinations of XTAI,
XTSL pin, double-speed command (DSPB), VCO1 selection command (VCOSEL1), VCO1 frequency division
commands (KSL3, KSL2) and command transfer rate selector (ASHS) in CLV-N or CLV-W mode.
Mode
1
2
3
4
5
6
7
XTAI
768Fs
768Fs
768Fs
768Fs
384Fs
384Fs
384Fs
XTSL
1
1
0
0
0
0
1
DSPB
0
1
0
1
0
1
1
VCOSEL1
∗1
0/1
0/1
1
1
0/1
0/1
0/1
ASHS
0
0
1
1
0
0
0
Playback speed
1×
2×
2×
4×
1×
2×
1×
Error correction
∗2
C1: double; C2: quadruple
C1: double; C2: double
C1: double; C2: quadruple
C1: double; C2: double
C1: double; C2: quadruple
C1: double; C2: double
C1: double; C2: double
∗1
Actually, the optimal value should be used together with KSL3 and KSL2.
∗2
When the ERC4 command of $8 = 1, C2 is quadruple correction even when DSPB = 1.
The playback speed can be varied by setting VP0 to VP7 in CAV-W mode. See "§3. Description of Modes" for
details.
§4-9. DAC Block Playback Speed
The operating speed of the DAC block is determined by the crystal and the MCSL command of $9X regardless
of the operating conditions of the CD-DSP block. This allows the DAC and CD-DSP block playback modes to
be set independently.
1-bit DAC block playback speed
X'tal
768Fs
768Fs
384Fs
1
0
0
1×
2×
1×
MCSL DAC block playback speed
Fs = 44.1kHz.
Page 92

§4-10. DAC Block Input Timing
The DAC block input timing is shown in Timing Chart 4-12.
The CXD2598Q enables data transfer from the CD signal processor block to the DAC block via an external
route. This makes it possible to send data to the DAC block via an external audio DSP, etc.
When the data is input to the DAC block without using an audio DSP, either EMPH, LRCK, BCK and PCMD
must be connected directly with EMPHI, LRCKI, BCKI and PCMDI outside the LSI, or the OUTL0 command of
$8X must be set to 1. Note that when the OUTL0 command of $8X is set to 1, the EMPH, LRCK, BCK and
PCMD outputs are low.
§4-11. Description of DAC Block Functions
Zero data detection
When the condition where the lower 4 bits of the input data are DC and the remaining upper bits are all "0" or
all "1" has continued for about 300ms (16384/44.1kHz), zero data is detected. Zero data detection is performed
independently for the left and right channels.
Mute flag output
The LMUT and RMUT pins go active when any one of the following conditions is met.
The polarity can be selected with the ZDPL command of $9X.
• When zero data is detected
• When a high signal is input to the SYSM pin
• When the DAC SMUTL and DAC SMUTR commands of $9X are set (The flags change independently
for the left and right channels.)
The mute flag outputs during initialize are as follows. (When zero data is input from LRCKI, BCKI and
PCMDI, and ZDPL of address $9 and MCSL of address $A are the initial values for the period in the figure
below.)
– 92 –
CXD2598Q
A
Y1
B
Y3
C
Y2
23.2 [ms]
–∞
000 (H)
0dB
400 (H)
XRST
LMUT
RMUT
Approximately 370ms when crystal = 16.9344MHz
Approximately 185ms when crystal = 33.8688MHz
Attenuation operation
Assuming the attenuation commands X1, X3 and X2, the corresponding audio outputs are Y1, Y2 and Y3
(Y1 > Y3 > Y2). First, the command X1 is sent and then the audio output approaches Y1. When the
command X2 is sent before the audio output reaches Y1 (A in the figure), the audio output passes Y1 and
approaches Y2. In addition, when the command X3 is sent before the audio output reaches Y2 (B or C in the
figure), the audio output approaches Y3 from the value (B or C in the figure) at that point.
Page 93
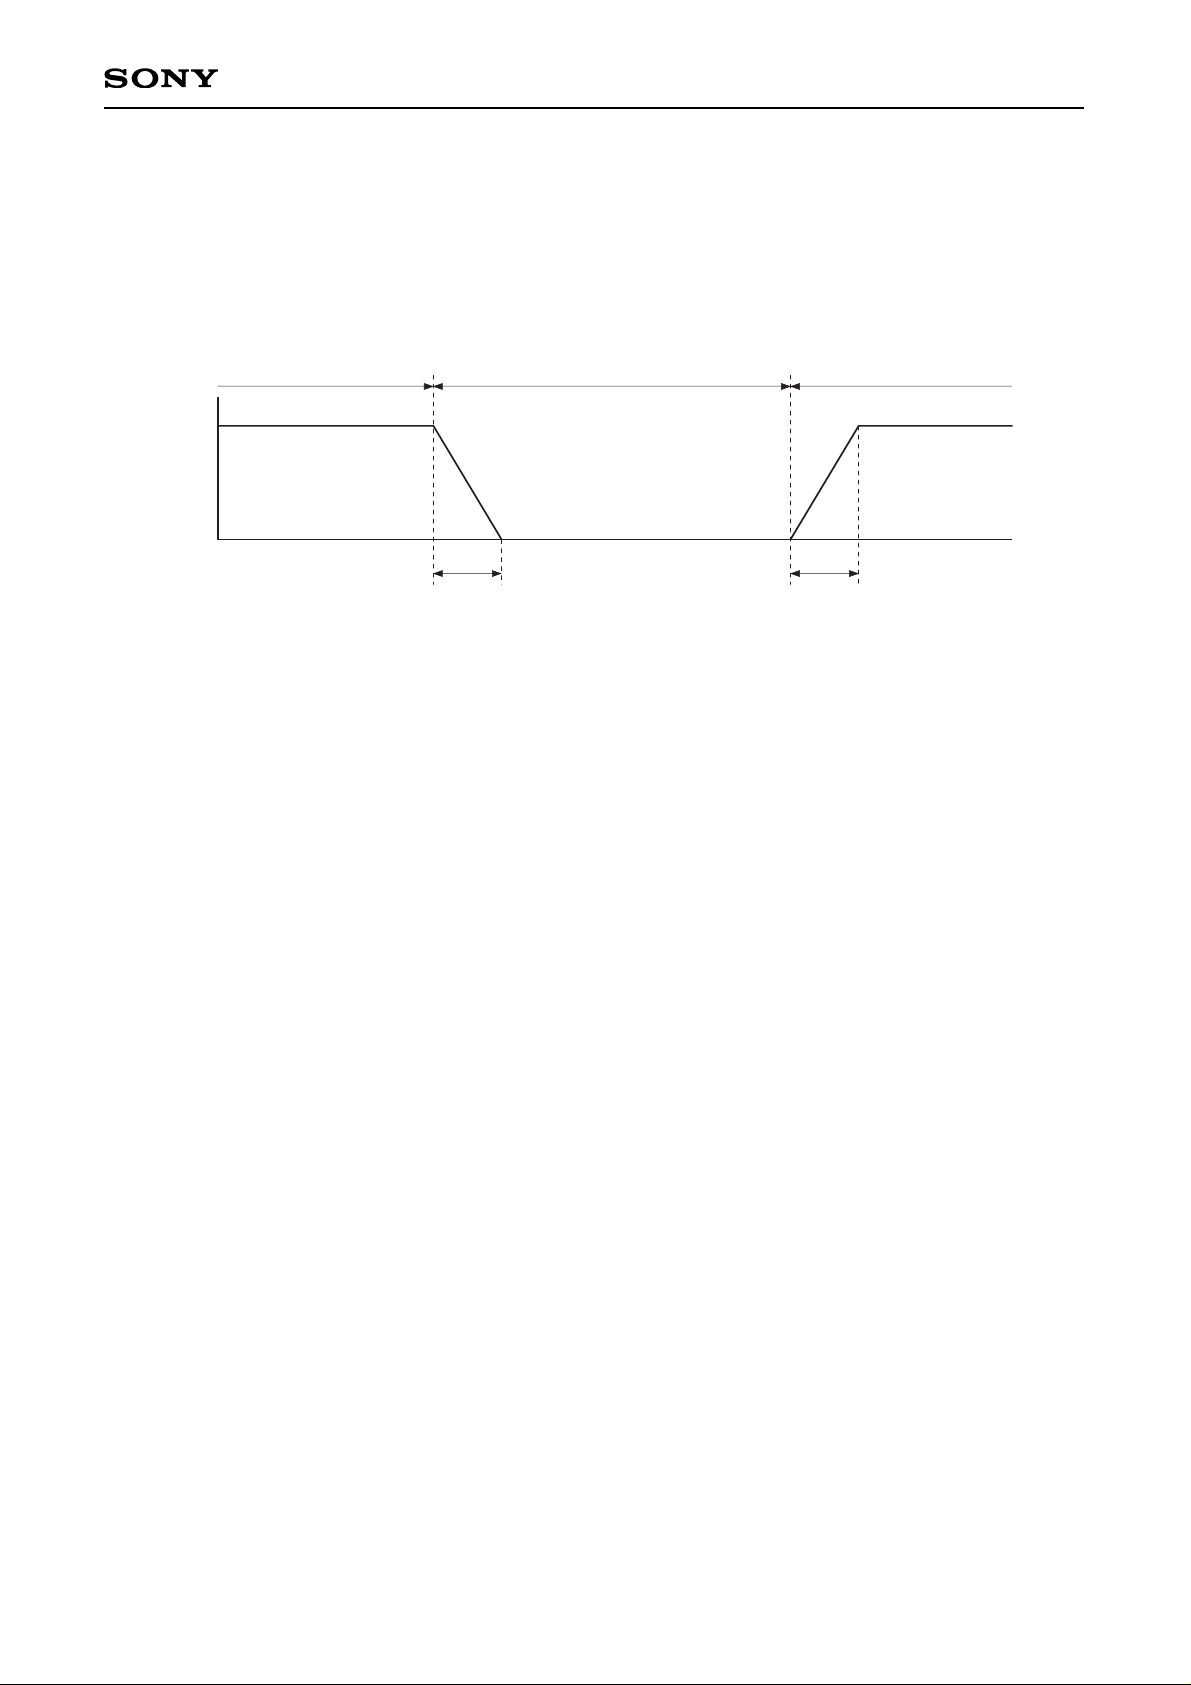
– 93 –
CXD2598Q
DAC block mute operation
Soft mute
Soft mute results and the input data is attenuated to zero when any one of the following conditions is met.
• When attenuation data of 000 (high) is set
• When the DAC SMUTL and DAC SMUTR commands of $9X are set to 1
• When a high signal is input to the SYSM input pin
Forced mute
Forced mute results when the FMUT command of $AX is set to 1.
Forced mute fixes the PWM output that is input to the LPF block to low.
Zero detection mute
Forced mute is applied when the ZMUT command of $9X is set to 1 and the zero data is detected for the
left and right channels. (See "Zero data detection".)
When the ZMUT command of $9X is set to 1, the forced mute is applied even if the mute flag output
condition is met. When the zero detection mute is on, set the DCOF command of $9X to 1.
Soft mute ON Soft mute OFFSoft mute OFF
23.2 [ms] 23.2 [ms]
0dB
–∞dB
Page 94

– 94 –
CXD2598Q
DAC Block Input Timing
Normal-Speed Playback
LRCKI
(44.1k)
BCKI
(2.12M)
1
24
PCMDI
R0
Lch MSB (15)
L14 L13 L12 L11 L10 L9 L8 L7 L6 L5 L4 L3 L2 L1 L0 RMSB
PCMDI
LRCKI
(88.2k)
BCKI
(4.23M)
Double-Speed Playback
24
R0
Lch MSB (15)
Rch MSB
2 3 4 5 6 7 8 9 10 11 12
1
2
L0
Timing Chart 4-12
Page 95

– 95 –
CXD2598Q
LRCK Synchronization
Synchronization is performed at the first rising edge of the LRCK input during reset.
After that, synchronization is lost when the LRCK input frequency changes and resynchronization must be
performed.
The LRCK input frequency changes when the master clock of the LSI is switched and the playback speed
changes such as the following cases.
• When the XTSL pin switches between high and low
• When the DSPB command of $9X setting changes
• When the MCSL command of $AX setting changes
• When operation switches between CLV mode and CAV mode
LRCK switching may also be performed if there are other ICs between the CD-DSP block and the DAC block.
Resynchronization must be performed in these cases as well.
For resynchronization, set the XWOC command of $9X to 0, wait for one LRCK cycle or more, and then set
XWOC to 1.
∗
When setting XWOC to 0, be sure to set the SYCOF command of $9X to 0 beforehand.
SYCOF
When LRCK, PCMD and BCK are connected directly with LRCKI, PCMDI and BCKI, respectively, playback
can be performed easily in CAV-W mode by setting SYCOF of address 9 to 1.
Normally, the memory proof, etc., is used for playback in CAV-W mode.
In CAV-W mode, the LRCK output conforms not to the crystal but to the VCO. Therefore, synchronization is
frequently lost.
Setting SYCOF of address 9 to 1 ignores when the LRCKI input synchronization is lost, facilitating playback.
However, the playback is not perfect because pre-value hold or data skip occurs due to the wow and flutter in
the LRCKI input.
∗
Set SYCOF to 0 other than when connecting LRCK, PCMD and BCK directly with LRCKI, PCMDI and
BCKI, respectively, and performing playback in CAV-W mode.
Page 96

– 96 –
CXD2598Q
Graph 4-13.
Digital Bass Boost
Bass boost without external parts is possible using the built-in digital filter. The boost strength has two levels:
Mid. and Max. BSBST and BBSL of address A are used for this setting.
See Graph 4-13 for the digital bass boost frequency response.
Normal
DBB MID
DBB MAX
10.00
–4.00
6.00
4.00
2.00
0.00
–2.00
8.00
–6.00
–8.00
–10.00
–12.00
–14.00
10 30 100 300 1k 3k 10k 30k
Digital Bass Boost Frequency Response [Hz]
[dB]
Page 97
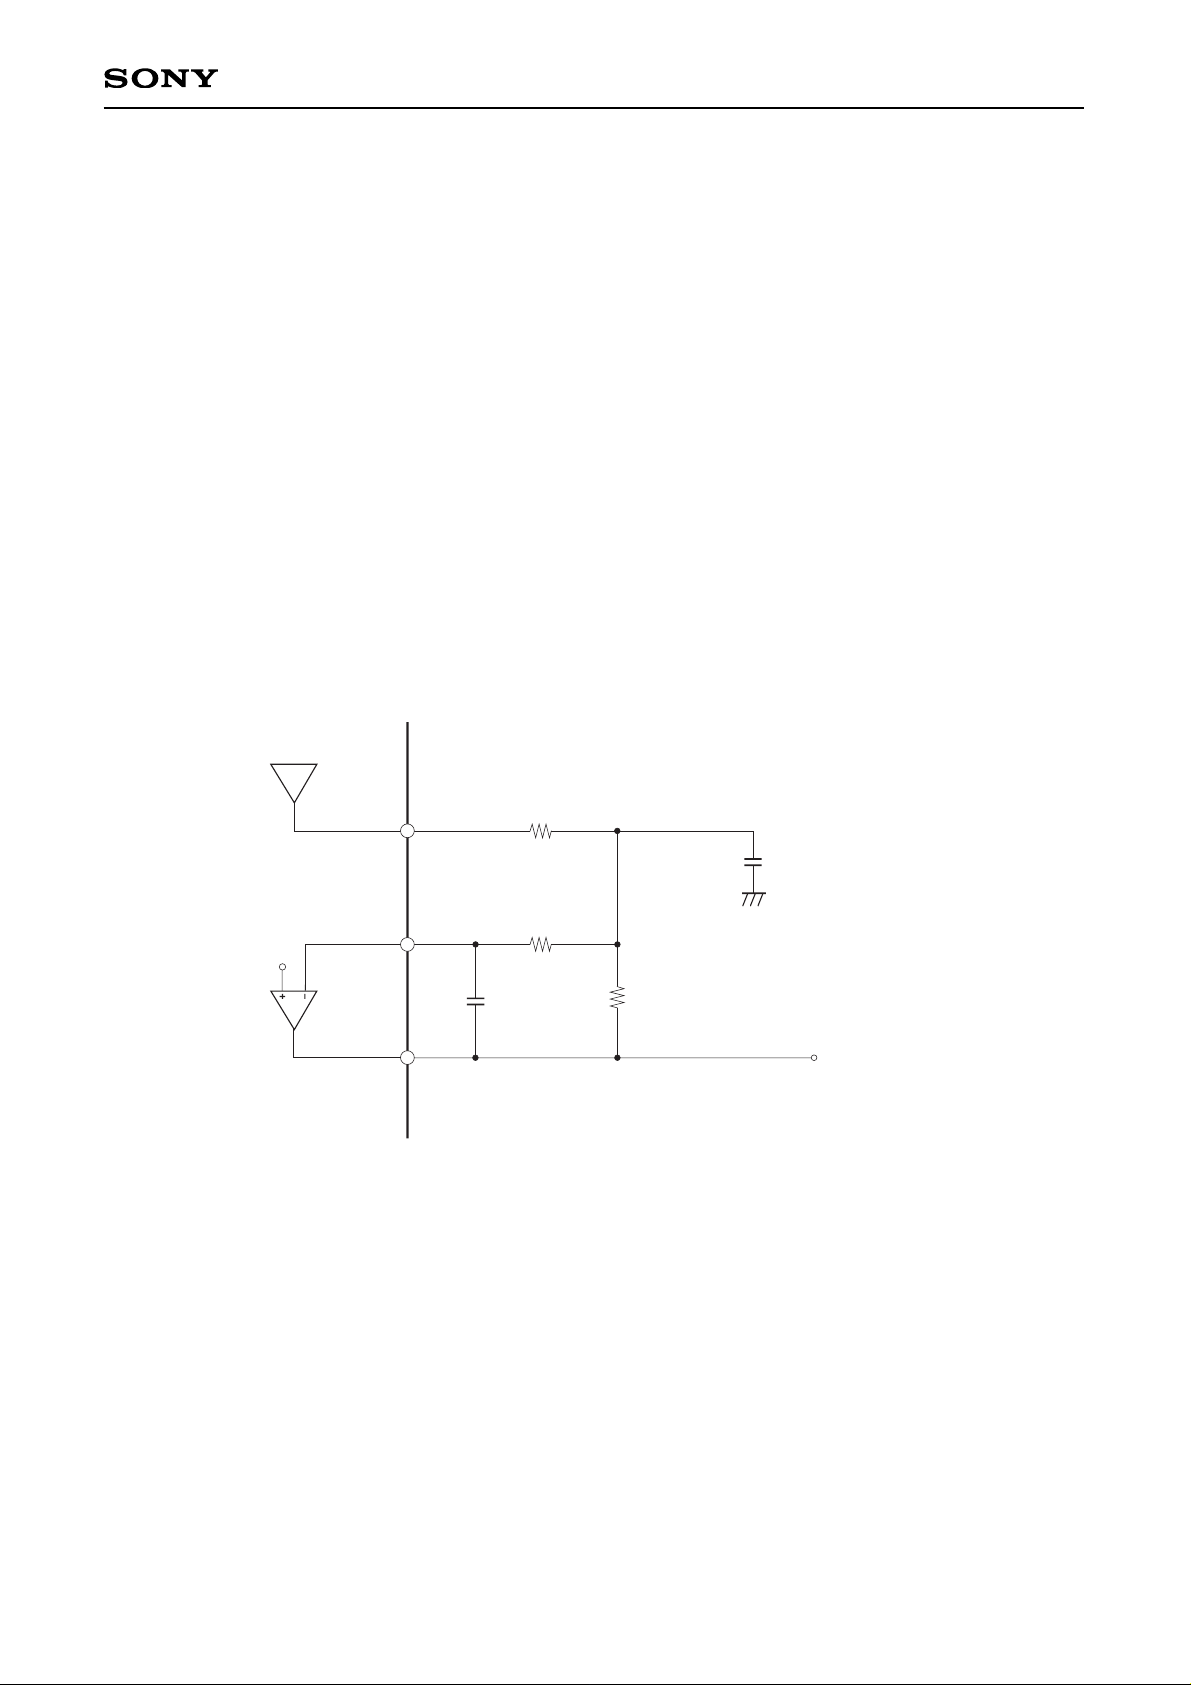
– 97 –
CXD2598Q
Analog out
C2
680p
12k
12k
12k
C1
150p
AOUT1 (2)
AIN1 (2)
LOUT1 (2)
Vc
Fig. 4-14. LPF External Circuit
§4-12. LPF Block
The CXD2598Q contains an initial-stage secondary active LPF with numerous resistors and capacitors and an
operational amplifier with reference voltage.
The resistors and capacitors are attached externally, allowing the cut-off frequency fc to be determined flexibly.
The reference voltage (Vc) is (AVDD – AVSS) × 0.43.
The LPF block application circuit is shown below.
In this circuit, the cut-off frequency is fc ≈ 40kHz.
The external capacitors' values when fc = 30kHz and 50kHz are noted below as a reference.
The resistors' values do not change at this time.
• When fc ≈ 30kHz:
C1 = 200pF, C2 = 910pF
• When fc ≈ 50kHz:
C1 = 120pF, C2 = 560pF
LPF Block Application Circuit
Page 98
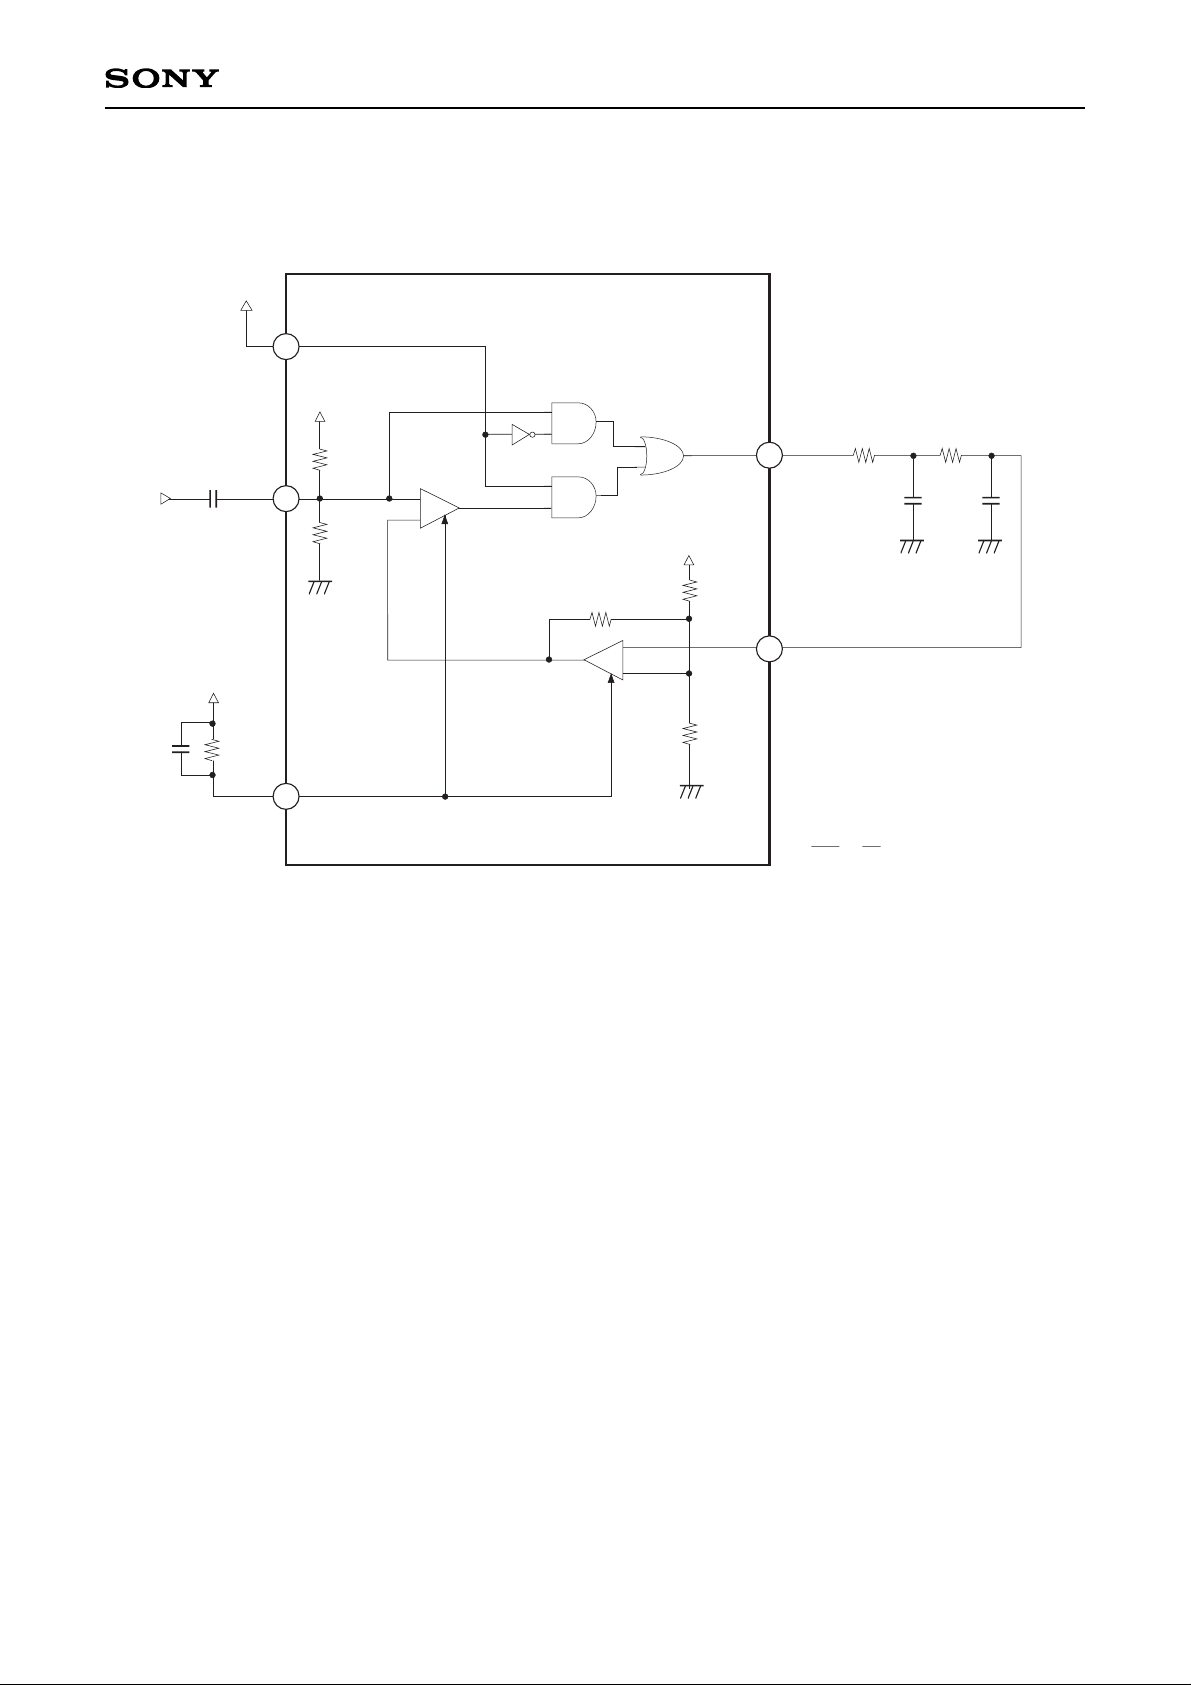
– 98 –
CXD2598Q
§4-13. Asymmetry Correction
Fig. 4-15 shows the block diagram and circuit example.
ASYE
RFAC
R1
R1
+
–
ASYO
ASYI
R1 2
R2 5
=
BIAS
R1
R1
R2
+
–
Fig. 4-15. Asymmetry Correction Application Circuit.
Page 99

– 99 –
CXD2598Q
§4-14. CD TEXT Data Demodulation
• In order to demodulate the CD TEXT data, set the command $8 Data 6 D3 TXON to 1. During TXON = 1, the
CD TEXT demodulation circuit occupies the EXCK and SBSO pins, so connect EXCK to low and do not use
the data output from SBSO. It requires 26.7ms (max.) to demodulate the CD TEXT data correctly after TXON
is set to 1.
• The CD TEXT data is output by switching the SQSO pin with the command. The CD TEXT data output is
enabled by setting the command $8 Data 6 D2 TXOUT to 1. To read data, the readout clock should be input
to SQCK.
• The readable data are the CRC counting results for each pack and the CD TEXT data (16 bytes) except for
CRC data.
• When the CD TEXT data is read, the order of the MSB and LSB is inverted within each byte. As a result,
although the sequence of the bytes is the same, the bits within the bytes are now ordered LSB first.
• Data which can be stored in the LSI is 1 packet (4 packs).
Fig. 4-16. Block Diagram of CD TEXT Demodulation Circuit
SQCK
SQSO
TXOUT
Subcode
Decoder
CD TEXT
Decoder
TXON
SBSO
EXCK
Page 100

– 100 –
CXD2598Q
CRC
4
CRC
3
CRC
2
CRC
1
0
0 0 0
S2 R2 W1 V1 U1 T1 S1 R1 U3 T3 S3 R3 W2 V2 U2 T2 W4 V4 U4 T4 S4
CRC Data
ID1 (Pack1)
ID2 (Pack1)
ID3 (Pack1)
16 Bytes
16 Bytes
16 Bytes
16 Bytes
4 bits
4 bits
Subcode Q Data
SCOR
TXOUT
(command)
SQCK
SQSO
SQCK
TXOUT
(command)
LSB
MSB
LSB MSB
LSB
CRC
0
Pack1
Pack2
Pack3
Pack4
CRCF
CRCF
80 Clocks
SQSO
520 Clocks
Fig. 4-17. CD TEXT Data Timing Chart
 Loading...