

Page 1

查询COP688EB供应商
COP888EB
8-Bit CMOS ROM Based Microcontrollers with 8k
Memory, CAN Interface, 8-Bit A/D, and USART
General Description
The COP888EB ROM based microcontrollers are highly integrated COP8
advanced features including a CAN 2.0B (passive) interface,
A/D and USART. These single-chip CMOS devices are
suited for applications requiring a full featured controller with
a CAN interface, low EMI, and versatile communications interfaces. COP87L8EB/RB devices are pin and software
compatible 16k or 32k OTP (One Time Programmable) versions for pre-production, and for use with a range of COP8
software and hardware development tools.
™
Feature core devices with 8k memory and
September 1999
Features include an 8-bit memory mapped architecture, 10
MHz CKI with 1µs instruction cycle, two multi-function 16-bit
timer/counters, WATCHDOG
2.0B (passive) interface, MICROWIRE/PLUS
SPI master/slave interface, fully buffered USART, 8-bit A/D
with 8 channels, two power saving HALT/IDLE modes,
MIWU, idle timer, software selectable I/O options, low EMI
4.5V to 5.5V operation, and 44/68 pin packages.
Note: A companion device with CAN interface, less I/O and
memory, and PWM timer is the COP888BC.
Devices included in this datasheet are:
™
and Clock Monitor, CAN
™
serial I/O,
COP888EB 8–Bit CMOS ROM Based Microcontrollers with 8k Memory, CAN Interface, 8–Bit A/D,
and USART
Device Memory (bytes) RAM (bytes) I/O Pins Packages Temperature
COP688EB 8k ROM 192 31 44 PLCC -55 to +125˚C
COP888EB 8k ROM 192 31 44 PLCC -40 to +85˚C
COP689EB 8k ROM 192 58 68 PLCC -55 to +125˚C
COP889EB 8k ROM 192 58 68 PLCC -40 to +85˚C
Key Features
n CAN bus interface, with Software Power save mode
n 8-bit A/D Converter with 8 channels
n Fully buffered USART
n Multi-input wake up (MIWU) on both Port L and M
n SPI Compatible Master/Slave Interface
n Quiet Design (Low Radiated Emissions)
n 8096 bytes of on-board ROM
n 192 bytes of on-board RAM
Additional Peripheral Features
n Idle timer (programmable)
n Two 16-bit timer, with two 16-bit registers supporting
— Processor independent PWM mode
— External Event counter mode
— Input capture mode
n WATCHDOG and Clock Monitor
n MICROWIRE/PLUS serial I/O
n Fourteen multi-sourced vectored interrupts servicing
— External interrupt
— Idle Timer T0
— Timers (T1 and T2) (4 Interrupts)
— MICROWIRE/PLUS and SPI
— Multi-input Wake up
— Software Trap
— CAN interface (3 interrupts)
— USART (2 Inputs)
n Versatile easy to use instruction set
n 8-bit stack pointer (SP) (Stack in RAM)
n Two 8-bit Register Indirect Memory Pointers (B, X)
Fully Static CMOS
n Two power saving modes: HALT, IDLE
n Single supply operation: 4.5V to 5.5V
n Temperature ranges: −40˚C to +85˚C and
−55˚C to +125˚C
Development Support
I/O Features
n Software selectable I/O options (TRI-STATE®outputs,
Push pull outputs, Weak pull up input, High impedance
input)
n Schmitt trigger inputs on Port G, L and M
n Packages: 44 PLCC with 31 I/O pins
68 PLCC with 58 I/O pins
n Emulation and OTP devices
n Real time emulation and full program debug offered by
MetaLink Development System
CPU/Instruction Set Features
n 1 µs instruction cycle time
COP8™, MICROWIRE™, MICROWIRE/PLUS™, and WATCHDOG™are trademarks of National Semiconductor Corporation.
®
TRI-STATE
is a registered trademark of National Semiconductor Corporation.
®
iceMASTER
is a registered trademark of MetaLink Corporation.
© 1999 National Semiconductor Corporation DS012837 www.national.com
Page 2

Basic Functional Description
n CAN I/F—CAN serial bus interface block as described
in the CAN specification part 2.0B (Passive)
— Interface rates up to 250k bit/s are supported utilizing
standard message identifiers
n Programmable double buffered USART
n A/D—8-bit, 8 channel, 1-LSB Resolution, with improved
Source Impedance and improved channel to channel
cross talk immunity
n Multi-Input-Wake-Up (MIWU)—edge selectable wake-up
and interrupt capability via input port and CAN interface
(Port L, Port M and CAN I/F); supports Wake-Up
capability on SPI, USART, and T2 capture
n Port C—8-bit bi-directional I/O port
n Port D—8-bit Output port with high current drive
capability (10 mA)
n Port F—8-bit bidirectional I/O
n Port G—8-bit bidirectional I/O port, including alternate
functions for:
— MICROWIRE
— Timer 1 Input or Output (Depending on mode
selected)
— External Interrupt input
— WATCHDOG Output
n Port I—8-bit input port combining either digital input, or
up to eight A/D input channels
n Port L—8-bit bidirectional I/O port, including alternate
functions for:
— USART Transmit/Receive I/O
— Multi-input-wake up (MIWU on all pins)
n Port M—8-bit I/O port, with the following alternate
function
— SPI Interface
— MIWU
™
Input and Output
— CAN Interface Wake-up (MSB)
— Timer 2 Input or Output (Depending on mode
selected)
n Port N—8-bit bidirectional I/O
— SPI Slave Select Expander
n Two 16-bit multi-function Timer counters (T1 and T2)
plus supporting registers
— (I/P Capture, PWM and Event Counting)
n Idle timer—Provides a basic time-base counter, (with
interrupt) and automatic wake up from IDLE mode
programmable
n MICROWIRE/PLUS—MICROWIRE serial peripheral
interface, supporting both Master and Slave operation
n HALT and IDLE—Software programmable low current
modes
— HALT—Processor stopped, Minimum current
— IDLE — Processor semi-active more than 60%power
saving
n 8 kBytes ROM and 192 bytes of on board static RAM
n SPI Master/Slave interface includes 12 bytes Transmit
and 12 bytes Receive FIFO Buffers. Operates up to 1M
Bit/S
n On board programmable WATCHDOG and CLOCK
Monitor
Applications
n Automobile Body Control and Comfort System
n Integrated Driver Informaiton Systems
n Steering Wheel Control
n Car Radio Control Panel
n Sensor/Actuator Applications in Automotive and
Industrial Control
Block Diagram
FIGURE 1. Block Diagram
www.national.com 2
DS012837-1
Page 3

Connection Diagrams
Plastic Chip Carrier
DS012837-2
Top View
Order Number COP888EB-XXX/V, COP688EB-XXX/V
See NS Plastic Chip Package Number V44A
Plastic Leaded Chip Carrier
Order Number COP889EB-XXX/V, COP689EB-XXX/V
Top View
See NS Plastic Chip Package Number V68A
FIGURE 2. Connection Diagrams
DS012837-3
www.national.com3
Page 4

Connection Diagrams (Continued)
Pinouts for 44-Pin and 68-Pin Packages
Port
Type
Pin Function PLCC PLCC
G0 I/O INT 44 1
G1 I/O WDOUT 1 2
G2 I/O T1B 2 3
G3 I/O T1A 3 4
G4 I/O SO 4 5
G5 I/O SK 5 6
G6 I SI 6 7
G7 I CKO 7 8
D0 O 17 27
D1 O 18 28
D2 O 19 29
D3 O 20 30
D4 O 31
D5 O 32
D6 O 33
D7 O 34
I0 I ADCH0 36 53
I1 I ADCH1 37 54
I2 I ADCH2 38 55
I3 I ADCH3 39 56
I4 I ADCH4 57
I5 I ADCH5 58
I6 I ADCH6 59
I7 I ADCH7 60
L0 I/O MIWU 40 61
L1 I/O MIWU;CKX 41 62
L2 I/O MIWU;TDX 42 63
L3 I/O MIWU;RDX 43 64
L4 I/O MIWU 65
L5 I/O MIWU 66
L6 I/O MIWU 67
L7 I/O MIWU 68
M0 I/O MIWU;MISO 21 38
M1 I/O MIWU;MOSI 22 39
M2 I/O MIWU;SCK 23 40
M3 I/O MIWU;SS
M4 I/O MIWU;T2A 25 42
M5 I/O MIWU;T2B 26 43
M6 I/O MIWU 27 44
N0 I/O ESS0 12 18
N1 I/O ESS1 13 19
N2 I/O ESS2 14 20
N3 I/O ESS3 15 21
N4 I/O ESS4 22
N5 I/O ESS5 23
N6 I/O ESS6 24
N7 I/O ESS7 25
ALT 44-Pin 68-Pin
24 41
Port
Type
Pin Function PLCC PLCC
ALT 44-Pin 68-Pin
F0 I/O 10
F1 I/O 11
F2 I/O 12
F3 I/O 13
F4 I/O 14
C0 I/O 35
C1 I/O 36
C2 I/O 37
RX0 I 31 48
RX1 I 30 47
TX0 O 29 46
TX1 O 28 45
CANV
REF
32 49
CKI 8 9
RESET 16 26
DV
CC
10, 33 16, 50
GND 9, 11, 34 15, 17, 51
A/D V
REF
35 52
www.national.com 4
Page 5

Absolute Maximum Ratings (Note 1)
If Military/Aerospace specified devices are required,
please contact the National Semiconductor Sales Office/
Distributors for availability and specifications.
Supply Voltage (V
Voltage at Any Pin −0.3V to V
)6V
CC
+0.3V
CC
Total Current into V
Pins (Source) 90 mA
CC
Total Current out of GND Pins (Sink) 100 mA
Storage Temperature Range −65˚C to +150˚C
Note 1:
Absolute maximum ratings indicate limits beyond which damage to
the device may occur. DC and AC electrical specifications are not ensured
when operating the device at absolute maximum ratings.
DC Electrical Characteristics COP88xEB
−40˚C ≤ TA≤ +85˚C
Parameter Conditions Min Typ Max Units
Operating Voltage 4.5 5.5 V
Power Supply Ripple (Note 2) Peak-to-Peak 0.1 V
Supply Current V
= 5.5V, tc=1µs 16 mA
CC
CC
CKI = 10 MHz (Note 3)
HALT Current (Notes 4, 5) V
IDLE Current (Note 5) V
= 5.5V, CKI=0MHz
CC
= 5.5V, tc= 1 µs 5.5 mA
CC
<
1µA
CKI = 10 MHz
Input Levels (V
IH,VIL
)
Reset, CKI
Logic High 0.8V
Logic Low 0.2V
CC
CC
All Other Inputs
Logic High 0.7V
Logic Low 0.2V
Hi-Z Input Leakage V
Input Pull-Up Current V
= 5.5V
CC
= 5.5V, VIN= 0V −40 −250 µA
CC
Port G, L and M Input Hysteresis (Note 8) 0.05V
CC
CC
±
2µA
CC
Output Current Levels
D Outputs
Source V
Sink V
= 4.5V, VOH= 3.3V −0.4 mA
CC
= 4.5V, VOL= 1.0V 10 mA
CC
CAN Transmitter Outputs
Source (Tx1) V
Sink (Tx0) V
= 4.5V, VOH=VCC−0.1V −1.5 mA
CC
V
= 4.5V, VOH=VCC− 0.6V −10 +5.0 mA
CC
= 4.5V, VOL= 0.1V 1.5 mA
CC
V
= 4.5V, VOL= 0.6V 10 mA
CC
All Others
Source (Weak Pull-Up) V
Source (Push-Pull) V
Sink (Push-Pull) V
TRI-STATE Leakage V
= 4.5V, VOH= 2.7V −10 −110 µA
CC
= 4.5V, VOH= 3.3V −0.4 mA
CC
= 4.5V, VOL= 0.4V 1.6 mA
CC
CC
= 5.5V
±
2.0 µA
Allowable Sink/Source Current per Pin
D Outputs (sink) 15 mA
Tx0 (Sink) (Note 8) 30 mA
Tx1 (Source) (Note 8) 30 mA
All Other 3mA
Maximum Input Current Room Temp
±
100 mA
without Latchup (Notes 6, 8)
RAM Retention Voltage, V
(Note 7) 500 ns Rise and Fall Time 2.0 V
r
Input Capacitance (Note 8) 7 pF
Load Capacitance on D2 1000 pF
Note 2: Maxiumum rate of voltage change must be<0.5V/ms
V
V
V
V
V
V
www.national.com5
Page 6

DC Electrical Characteristics COP88xEB (Continued)
Note 3: Supply current is measured after running 2000 cycles with a square wave CKI input, CKO open, inputs at VCCor GND, and outputs open.
Note 4: TheHALT mode will stop CKI from oscillating in the Crystal configurations. Halt test conditions: All inputs tied to V
figured as outputs and programmed low; D outputs programmed high. Parameter refers to HALT mode entered via setting bit 7 of the Port G data register. Part will
pull up CKI during HALT in crystal clock mode. Both CAN main comparator and the CAN Wakeup comparator need to be disabled.
Note 5: HALT and IDLE current specifications assume CAN block comparators are disabled.
Note 6: PinsG6 and RESET are designed with a high voltage input network. These pins allow input voltages greater than V
to VCCwhen biased at voltages greater than VCC(the pins do not have source current when biasedatavoltagebelowVCC). The effective resistancetoVCCis 750Ω
(typical). These two pins will not latch up. The voltage at the pins must be limited to less than 14V.
Note 7: Condition and parameter valid only for part in HALT mode.
Note 8: Parameter characterized but not tested.
; Port C, G, E, F, L, M and N I/Os con-
CC
and the pins will have sink current
CC
www.national.com 6
Page 7

Absolute Maximum Ratings (Note 9)
If Military/Aerospace specified devices are required,
please contact the National Semiconductor Sales Office/
Distributors for availability and specifications.
Supply Voltage (V
Voltage at Any Pin −0.3V to V
)7V
CC
+0.3V
CC
Total Current into V
Pins (Source) 100 mA
CC
Total Current out of GND Pins (Sink) 110 mA
Storage Temperature Range −65˚C to +150˚C
Note 9:
Absolute maximum ratings indicate limits beyond which damage to
the device may occur. DC and AC electrical specifications are not ensured
when operating the device at absolute maximum ratings.
DC Electrical Characteristics COP68xEB
−55˚C ≤ TA≤ +125˚C
Parameter Conditions Min Typ Max Units
Operating Voltage 4.5 5.5 V
Power Supply Ripple (Note 10) Peak-to-Peak 0.1 V
Supply Current V
= 5.5V, tc=1µs 16 mA
CC
CKI = 10 MHz (Note 11)
HALT Current (Notes 12, 13) V
IDLE Current (Note 13) V
= 5.5V, CKI = 0 MHz 10 µA
CC
= 5.5V, tc= 1 µs 5.5 mA
CC
CKI = 10 MHz
Input Levels (V
IH,VIL
)
Reset, CKI
Logic High 0.8V
CC
Logic Low 0.2V
All Other Inputs
Logic High 0.7V
CC
Logic Low 0.2V
Hi-Z Input Leakage V
Input Pull-Up Current V
Port G, L and M Input Hysteresis (Note 16) 0.05V
= 5.5V
CC
= 5.5V, VIN= 0V −35 −250 µA
CC
CC
Output Current Levels
D Outputs
Source V
Sink V
= 4.5V, VOH= 3.3V −0.4 mA
CC
= 4.5V, VOL= 1.0V 9.0 mA
CC
CAN Transmitter Outputs
Source (Tx1) V
Sink (Tx0) V
= 4.5V, VOH=VCC−0.1V −1.5 mA
CC
V
= 4.5V, VOH=VCC− 0.6V −10 mA
CC
= 4.5V, VOL= 0.1V 1.5 mA
CC
V
= 4.5V, VOL= 0.6V 10 mA
CC
All Others
Source (Weak Pull-Up) V
Source (Push-Pull) V
Sink (Push-Pull) V
TRI-STATE Leakage V
= 4.5V, VOH= 2.7V −9.0 −100 µA
CC
= 4.5V, VOH= 3.3V −0.4 mA
CC
= 4.5V, VOL= 0.4V 1.4 mA
CC
= 5.5V
CC
Allowable Sink/Source Current per Pin
D Outputs (sink) 12 mA
Tx0 (Sink) (Note 16) 30 mA
Tx1 (Source) (Note 16) 30 mA
All Other 2.5 mA
Maximum Input Current Room Temp
without Latchup (Notes 14, 16)
RAM Retention Voltage, V
(Note 15) 500 ns Rise and Fall Time 2.0 V
r
Input capacitance (Note 16) 7 pF
Load Capacitance on D2 1000 pF
Note 10: Maxiumum rate of voltage change must be<0.5V/ms
CC
CC
CC
±
5µA
±
5.0 µA
±
100 mA
V
V
V
V
V
V
www.national.com7
Page 8

DC Electrical Characteristics COP68xEB (Continued)
Note 11: Supply current is measured after running 2000 cycles with a square wave CKI input, CKO open, inputs at VCCor GND, and outputs open.
Note 12: TheHALT mode will stop CKI from oscillating in the Crystal configurations. Halt test conditions: All inputs tied to V
figured as outputs and programmed low; D outputs programmed high. Parameter refers to HALT mode entered via setting bit 7 of the Port G data register. Part will
pull up CKI during HALT in crystal clock mode. Both CAN main comparator and the CAN Wakeup comparator need to be disabled.
Note 13: HALT and IDLE current specifications assume CAN block comparators are disabled.
Note 14: PinsG6 and RESET are designed with a high voltage input network. These pins allow input voltages greater than V
to VCCwhen biased at voltages greater than VCC(the pins do not have source current when biasedatavoltagebelowVCC). The effective resistancetoVCCis 750Ω
(typical). These two pins will not latch up. The voltage at the pins must be limited to less than 14V.
Note 15: Condition and parameter valid only for part in HALT mode.
Note 16: Parameter characterized but not tested.
; Port C, G, E, F,L,MandNI/Oscon-
CC
and the pins will have isnk current
CC
AC Electrical Characteristics COP68xEB and COP88xEB
−55˚C ≤ TA≤ +125˚C
Parameter Conditions Min Typ Max Units
Instruction Cycle Time (t
Crystal/Resonator V
Inputs
t
SETUP
t
HOLD
Output Propagation Delay (t
SK, SO V
All others V
MICROWIRE
Setup Time (t
Hold Time (t
UWH
Output Pop Delay (t
Input Pulse Width
Interrupt High Time 1 t
Interrupt Low Time 1t
Timer 1, 2 High Time 1 t
Timer 1, 2 Low Time 1 t
Reset Pulse Width (Note 20) 1.0 µs
tc= Instruction Cycle Time
Note 17: Themaximum bus speed achievable with the CAN interface is a function of crystal frequency, message length and software overhead. The device can sup-
port a bus speed of up to 1 Mbit/S with a 10 MHz oscillator and 2 byte messages. The 1M bus speed refers to the rate at which protocol and data bits are transferred
on the bus. Longer messages require slower bus speeds due to the time required for software intervention between data bytes. The device will support a maximum
of 125k bits/s with eight byte messages and a 10 MHz oscillator.
Note 18: For device testing purpose of all AC parameters, V
Note 19: The output propagation delay is referenced to the end of the instruction cycle where the output change occurs.
Note 20: Parameter not tested.
)
c
≥ 4.5V 1.0 DC µs
CC
VCC≥ 4.5V 200 ns
VCC≥ 4.5V 60 ns
) (Note 19) CL= 100 pF, RL= 2.2 kΩ
PD1,tPD0
) (Note 20) 20 ns
UWS
≥ 4.5V 0.7 µs
CC
≥ 4.5V 1 µs
CC
) (Note 20) 56 ns
) 220 ns
UPD
will be tested at 0.5*VCC.
OH
c
c
c
c
On-Chip Voltage Reference
−55˚C ≤ TA≤ +125˚C
Parameter Conditions Min Max Units
<
Reference Voltage I
V
REF
Reference Supply I
Current, I
DD
Note 21: Reference supply IDDis supplied for information purposes only, it is not tested.
www.national.com 8
80 µA, 0.5VCC−0.12 0.5VCC+0.12 V
OUT
VCC=5V
= 0A, (No Load) 120 µA
OUT
VCC= 5V (Note 21)
Page 9

CAN Comparator DC and AC Characteristics
4.8V ≤ VCC≤ 5.2V, −40˚C ≤ TA≤ +125˚C
Parameter Conditions Min Typ Max Units
±
Differential Input Voltage
<
Input Offset Voltage 1.5V
V
<
IN
VCC−1.5V
Input Common Mode 1.5 V
25 mV
±
10 mV
−1.5 V
CC
Voltage Range
Input Hysteresis 8 mV
A/D Converter Specifications
(4.5V ≤ VCC≤ 5.5V) (VSS− 0.050V) ≤ Any Input ≤ (VCC+ 0.050V)
Parameter Conditions Min Typ Max Units
Resolution 8 Bits
Absolute Accuracy V
REF=VCC
Non-Linearity
Deviation from the Best Straight Line
Differential Non-Linearity
Common Mode Input Range (Note 24) GND V
DC Common Mode Error
Off Channel Leakage Current 1 2.0 µA
On Channel Leakage Current 1 2.0 µA
A/D Clock Frequency (Note 23) 0.1 1.67 MHz
Conversion Time (Note 22) 17 A/D Clock Cycles
Internal Reference Resistance Turn-On Time (Note 25) 1 µs
Note 22: ConversionTime includes sample and hold time.
Note 23: See Prescaler description.
Note 24: ForV
input voltages below ground or above the V
to conduct — especially at elevated temperatures, and cause errors for analog inputs near full-scale. The spec allows 50 mV forward bias of either diode. This means
that as long as the analog V
voltage range will therefore require a minimum supply voltage of 4.950 V
Note 25: Time for internal reference resistance to turn on after coming out of Halt or Idle Mode.
(−)>=VIN(+) the digital output code will be 0000 0000. Twoon-chip doides are ties to each analog input. The diodes will forward conduct for analog
IN
does not exceed the supply voltage by more than 50 mV, the output code will be correct. To achieve an absolute 0 VDCto 5 VDCinput
IN
supply.Be careful, during testing at low VCClevels (4.5V), as high level analog inputs (5V) can cause this input diode
CC
over temperature variations, initial tolerance and loading.
DC
±
2 LSB
±
1 LSB
±
1 LSB
CC
±
0.5 LSB
V
DS012837-4
FIGURE 3. MICROWIRE/PLUS Timing Diagram
www.national.com9
Page 10

A/D Converter Specifications (Continued)
FIGURE 4. SPI Timing Diagram
Typical Performance Characteristics (−55˚C ≤ T
A
=
+125˚C)
DS012837-5
DS012837-57 DS012837-58
DS012837-59 DS012837-60
www.national.com 10
Page 11

Typical Performance Characteristics (−55˚C ≤ T
DS012837-61
Pin Description
VCCand GND are the power supply pins.
CKI is the clock input. The clock can come from a crystal os-
cillator (in conjunction with CKO). See Oscillator Description
section.
RESET is the master resetinput. See Reset Description section.
The device contains seven bidirectional 8-bit I/O ports (C, E,
F, G, L, M, N) where each individual bit may be independently configured as an input (Schmitt trigger inputs on all
ports), output or TRI-STATE under program control. Three
data memory address locations are allocated for each of
these I/O ports. Each I/O port has two associated 8-bit
memory mapped registers, the CONFIGURATION register
and the output DATA register.A memory mapped address is
also reserved for the input pins of each I/O port. (See the
memory map for the various addresses associated with the
I/O ports.)
device. The DATA and CONFIGURATION registers allow for
each port bit to be individually configured under software
control as shown below:
Port L and M are 8-bit I/O ports, they support Multi-Input
Wake-up (MIWU) on all eight pins. All L-pins and M-pins
have Schmitt triggers on the inputs.
Port L and M only have one (1) interrupt vector.
Figure 5
shows the I/O port configurations for the
Configuration Data Port Set-Up
Register Register
0 0 Hi-Z Input
(TRI-STATE Output)
0 1 Input with Weak Pull-Up
1 0 Push-Pull Zero Output
1 1 Push-Pull One Output
Port L has the following alternate features:
L7 MIWU
L6 MIWU
L5 MIWU
L4 MIWU
L3 MIWU or RDX
L2 MIWU or TDX
L1 MIWU or CKX
L0 MIWU
Port G is an 8-bit port with 5 I/O pins (G0–G5), an input pin
(G6), and one dedicated output pin (G7). Pins G0–G6 all
have Schmitt Triggers on their inputs. G7 serves as the dedicated output pin for the CKO clock output. There are two registers associated with the G Port, a data register and a configuration register. Therefore, each of the 6 I/O bits (G0–G5)
can be individually configured under software control.
Since G6 is an input only pin and G7 is the dedicated CKO
clock output pin the associated bits in the data and configuration registers for G6 and G7 are used for special purpose
functions as outlined below. Reading the G6 and G7 data
bits will return zeroes.
Note that the chip will be placed in the HALTmode by wirting
a ’’1” to bit 7 of the Port G Data Register. Similarly the chip
will be placed in the IDLE mode by writing a “1” to bit 6 of the
Port G Data Register.
=
+125˚C) (Continued)
A
FIGURE 5. I/O Port Configurations
DS012837-6
www.national.com11
Page 12

Pin Description (Continued)
Writing a “1” to bit 6 of the Port G Configuration Register enables the MICROWIRE/PLUS to operate with the alternate
phase of the SK clock
Config. Reg. Data Reg.
G7 CLKDLY HALT
G6 Alternate SK IDLE
Port G has the following alternate features:
G6 SI (MICROWIRE Serial Data Input)
G5 SK (MICROWIRE Serial Clock)
G4 SO (MICROWIRE Serial Data Output)
G3 T1A (Timer I/O)
G2 (Timer T1 Capture Input)
G1 Dedicated WATCHDOG output
G0 INTR (External Interrupt Input)
Port G has the following dedicated function:
G7 CKO Oscillator dedicated output
Port M is a bidirectional I/O, it may be configured in software
as Hi-Z input, weak pull-up, or push-pull output. These pins
may be used as general purpose input/output pins or for selected altlernate functions.
Port M pins have optional alternate functions. Each pin
(M0–M5) has been assigned an alternate data, configuration, or wakeup source. If the respective alternate function is
selected the content of the associated bits in the configuration and/or data register are ignored. If an alternate wakeup
source is selected the input level at the respective pin will be
ignored for the purpose of triggering a wakeup event, however it will still be possible to read that pin by accessing the
input register. The SPI (Serial Peripheral Interface) block, for
example, uses four of the Port M pins to automatically reconfigure its MISO (Master Input, Slave Output), MOSI
(Master Output, Slave Input), SCK (Serial Clock) and SlaveSelect pins as inputs or outputs, depending on whether the
interface has been configured as a Master or Slave. When
the SPI interface is disabled those pins are available as general purpose I/O pins configurable by user software writing to
the associated data and configuration bits. The CAN interface on the device makes use of one of the Port M’s alternate wake-ups, to trigger a wakeup if such a condition has
been detected on the CAN’s dedicated receive pins.
Port M has the following alternate pin functions:
M7 Multi-input Wakeup or CAN
M6 Multi-input Wakeup
M5 Multi-input Wakeup or T2B
M4 Multi-input Wakeup or T2A
M3 Multi-input Wakeup or SS
M2 Multi-input Wakeup or SCK
M1 Multi-input Wakeup or MOSI
M0 Multi-input Wakeup or MISO
Ports C, E, F and N are general-purpose, bidirectional I/O
ports.
Any device package that has Port C, E, F,M, N but has fewer
than eight pins, contains unbonded, floating pads internally
on the chip. For these types of devices, the software should
writea1totheconfiguration register bits corresponding to
the non-existent port pins. This configures the port bits as
outputs, thereby reducing leakage current of the device.
Port N is an 8-bit wide port with alternate function capability
used for extending the slave select (SS) lines of the on SPI
interface. The SPI expander block provides mutually exclusive slave select extension signals (ESS0 to ESS7) according to the state of the SS line and specific contents of the SPI
shift register. These slave select extension lines can be
routed to the Port N I/O pins by enabling the alternate function of the port in the PORTNX register. If enabled, the internal signal on the ESSx line causes the ports state to change
exactly like a change to the PORTND register. It is the user’s
responsibility to switch the port to an output when enabling
the alternate function.
Port N has the following alternate pin functions:
N7 ESS7
N6 ESS6
N5 ESS5
N4 ESS4
N3 ESS3
N2 ESS2
N1 ESS1
N0 ESS0
CAN pins: For the on-chip CAN interface this device has five
dedicated pins with the following features:
V
On-chip reference voltage with the value of VCC/2
REF
Rx0 CAN receive data input pin.
Rx1 CAN receive data input pin.
Tx0 CAN transmit data output pin. This pin may be put in
the TRI-STATE mode with the TXEN0 bit in the CAN
Bus control register.
Tx1 CAN transmit data output pin. This pin may be put in
the TRI-STATE mode with the TXEN1 bit in the CAN
Bus control register.
ALTERNATE PORT FUNCTIONS
Many general-purpose pins have alternate functions. The
software can program each pin to be used either for a
general-purpose or for a specific function.The chiphardware
determines which of the pins have alternate functions, and
what those functions are. This section lists the alternate
functions available on each of the pins.
Port D is an 8-bit output port that is preset high when RESET
goes low. The user can tie two or more port D outputs (except D2) together in order to get a higher drive.
Note: Care must be exercised with D2 pin operation. At RESET, the external
loads on this pin must ensure that the output voltages stay above 0.8
to prevent the chip from entering special modes.Also keep the ex-
V
CC
ternal loading on D2 to
<
1000 pF.
Port I is an 8-bit Hi-Z input port, and also provides the analog
inputs to the A/D converter. If unterminated, Port I pins will
draw power only when addressed.
Functional Description
The architecture of the device utilizes a modified Harvard architecture. With the Harvard architecture, the control store
program memory (ROM) is separated from the data store
memory (RAM). Both ROM and RAM have their own separate addressing space with separate address buses. The architecture, though based on Harvard architecture, permits
transfer of data from ROM to RAM.
www.national.com 12
Page 13

Functional Description (Continued)
CPU REGISTERS
The CPU can do an 8-bit addition, subtraction, logical or shift
operation in one instruction (t
There are five CPU registers:
A is the 8-bit Accumulator Register
PC is the 15-bit Program Counter Register
PU is the upper 7 bits of the program counter (PC)
PL is the lower 8 bits of the program counter (PC)
B is an 8-bit RAM address pointer, which can be optionally
post auto incremented or decremented.
X is an 8-bit alternate RAM address pointer, which can be
optionally post auto incremented or decremented.
SP is the 8-bit stack pointer, which points to the subroutine/
interrupt stack (in RAM). The SP is initialized to RAM address 02F with reset.
All the CPU registers are memory mapped with the exception of the Accumulator (A) and the Program Counter (PC).
PROGRAM MEMORY
Program memory for the device consists of 8 kbytes of ROM.
These bytes may hold program instructions or constant data
(data tables for the LAID instruction, jump vectors for the JID
instruction and interrupt vectors for the VIS instruction). The
program memory is addressed by the 15-bit program
counter (PC). All interrupts in the device vector to program
memory location 0FF Hex.
DATA MEMORY
The data memory address space includes the on-chip RAM
and data registers, theI/O registers (Configuration, Data and
Pin), the control registers, the MICROWIRE/PLUS SIO shift
register, and the various registers, and counters associated
with the timers (with the exception of the IDLE timer). Data
memory is addressed directly by the instruction or indirectly
by the B, X and SP pointers.
The device has 192 bytes of RAM. Sixteen bytes of RAM are
mapped as “registers” at addresses 0F0 to 0FF Hex. These
registers can be loaded immediately, and also decremented
and tested with the DRSZ (decrement register and skip if
zero) instruction. The memory pointer registers X, SP,and B
are memory mapped into this space at address locations
0FC to 0FE Hex respectively, with the other registers (other
than reserved register 0FF) being available for general usage.
The instruction set permits any bit in memory to be set, reset
or tested. All I/O and registers (except A and PC) are
memory mapped; therefore I/O bits and register bits can be
directly and individually set, reset and tested. The accumulator (A) bits can also be directly and individually tested.
Note: RAM contents are undefined upon power-up.
RESET
The RESET input when pulled low initializes the microcontroller. Initialization will occur whenever the RESET input is
pulled low. Upon initialization, the data and configuration
registers for Ports L and G, are cleared, resulting in these
Ports being initialized to the TRI-STATE mode. Port D is initialized high with RESET. The PC, CNTRL, and INCTRL
control registers are cleared. The Multi-Input Wakeup registers WKEN, WKEDG, and WKPND are cleared. The Stack
Pointer, SP, is initialized to 06F Hex.
The following initializations occur with RESET:
) cycle time.
c
SPI:
SPICNTRL: Cleared
SPISTAT: Cleared
STBE Bit: Set
T1CNTRL & T2CNTRL: Cleared
ITMR: Cleared and IDLE timer period is reset to 4k Instr.
CLK
ENAD: Cleared
ADDSLT: Random
SIOR: Unaffected after RESET with power already ap-
plied.
Random after RESET at power on.
Port L: TRI-STATE
Port G: TRI-STATE
Port D: HIGH
PC: CLEARED
PSW, CNTRL and ICNTRL registers: CLEARED
Accumulator and Timer 1:
RANDOM after RESET with power already applied
RANDOM after RESET at power-on
SP (Stack Pointer): Loaded with 6F Hex
B and X Pointers:
UNAFFECTED after RESET with power already applied
RANDOM after RESET at power-up
RAM:
UNAFFECTED after RESET with power already applied
RANDOM after RESET at power-up
CAN: The CAN Interface comes out of external reset in the
“error-active” state and waits until the user’s software sets either one or both of the TXEN0, TXEN1
bits to “1”. After that, the device will not start transmission or reception of a frame util eleven consecutive “recessive” (undriven) bits have been received.
This is done to ensure that the output drivers are not
enamble during an active message on the bus.
CSCAL, CTIM, TCNTL, TEC, REC: CLEARED
RTSTAT: CLEARED with the exception of the TBE bit which
is set to 1
RID, RIDL, TID, TDLC: RANDOM
WATCHDOG: The device comes out of reset with both the
WATCHDOG logic and the Clock Monitor
detector armed, with the WATCHDOG service window bits set and the Clock Monitor
bit set. The WATCHDOG and Clock Monitor
circuits are inhibited during reset. The
WATCHDOG service window bits being initialized high default to the maximum
WATCHDOG service window of 64k t
cycles. The Clock Monitor bit being initial-
c
clock
ized high will cause a Clock Monitor bit being initialized high will cause a Clock Monitor error following reset if the clock has not
reached the minimum specified frequency
at the termination of reset. A Clock Monitor
error will cause an active low error output on
pin G1. This error output will continue until
16 t
–32 tcclock cycles following the clock
c
frequency reaching the minimum specified
value, at which time the G1 output will enter
the TRI-STATE mode.
www.national.com13
Page 14

Functional Description (Continued)
The RESET signal goes directly to the
HALT latch to restart a halted chip.
When using external reset, the external RC network shown
in
Figure 6
should be used to ensure that the RESET pin is
held low until the power supply to the chip stabilizes. Under
no circumstances should the RESET pin be allowed to float.
RC>5 x Power Supply Rise Time
DS012837-7
FIGURE 6. Recommended Reset Circuit
Oscillator Circuits
The chip can be driven by a clock input on the CKI input pin
which can be between DC and 10 MHz. The CKO output
clock is on pin G7. The CKI input frequency is divided by 10
to produce the instruction cycle clock (1/t
Figure 7
shows the Crystal diagram.
).
c
CRYSTAL OSCILLATOR
CKI and CKO can be connected to make a closed loop crystal (or resonator) controlled oscillator.
DS012837-8
FIGURE 7. Crystal Oscillator Diagram
Table 1 shows the component values required for various
standard crystal values.
TABLE 1. Crystal Oscillator Configuration, TA= 25˚C
R1 R2 C1 C2 CKI Freq. Conditions
(kΩ)(MΩ) (pF) (pF) (MHz)
0 1 30 30–36 10 V
0 1 30 30–36 4 V
0 1 200 100–150 0.455 V
=5V
CC
=5V
CC
=5V
CC
Control Registers
CNTRL Register (Address X'00EE)
T1C3 T1C2 T1C1 T1C0 MSEL IEDG SL1 SL0
Bit 7 Bit 0
The Timer1 (T1) and MICROWIRE/PLUS control register
contains the following bits:
T1C3 Timer T1 mode control bit
T1C2 Timer T1 mode control bit
T1C1 Timer T1 mode control bit
T1C0 Timer T1 Start/Stop control in timer
modes 1 and 2, T1 Underflow Interrupt
Pending Flag in timer mode 3
MSEL Selects G5 and G4 as MICROWIRE/PLUS
signals SK and SO respectively
IEDG External interrupt edge polarity select
(0 = Rising edge, 1 = Falling edge)
SL1 & SL0 Select the MICROWIRE/PLUS clock divide
by (00 = 2, 01 = 4, 1x = 8)
PSW Register (Address X'00EF)
HC C T1PNDA T1ENA EXPND BUSY EXEN GIE
Bit 7 Bit 0
The PSW register contains the following select bits:
HC Half Carry Flag
C Carry Flag
T1PNDA Timer T1 Interrupt Pending Flag (Autoreload
RA in mode 1, T1 Underflow in Mode 2, T1A
capture edge in mode 3)
T1ENA Timer T1 Interrupt Enable for Timer Underflow
or T1A Input capture edge
EXPND External interrupt pending
BUSY MICROWIRE/PLUS busy shifting flag
EXEN Enable external interrupt
GIE Global interrupt enable (enables interrupts)
The Half-Carry flag is also affected by all the instructions that
affect the Carry flag. The SC (Set Carry) and R/C (Reset
Carry) instructions will respectively setor clear both the carry
flags. In addition to the SC and R/C instructions, ADC,
SUBC, RRC and RLC instructions affect the Carry and Half
Carry flags.
ICNTRL Register (Address X'00E8)
Reserved LPEN T0PND T0EN µWPND µWEN T1PNDB T1ENB
Bit 7 Bit 0
www.national.com 14
Page 15

Control Registers (Continued)
The ICNTRL register contains the following bits:
Reserved This bit is reserved and should be zero
LPEN L Port/M Port Interrupt Enable (Multi-Input
Wakeup/Interrupt)
T0PND Timer T0 Interrupt pending
T0EN Timer T0 Interrupt Enable (Bit 12 toggle)
µWPND MICROWIRE/PLUS interrupt pending
µWEN Enable MICROWIRE/PLUS interrupt
T1PNDBTimer T1 Interrupt Pending Flag for T1B capture
edge
T1ENB Timer T1 Interrupt Enable for T1B Input capture
edge
T2CNTRL Register (Address X'00C6)
T2C3 T2C2 T2C1 T2C0 T2PNDA T2ENA T2PNDB T2ENB
Bit 7 Bit 0
The T2CNTRL control register contains the following bits:
T2C3 Timer T2 mode control bit
T2C2 Timer T2 mode control bit
T2C1 Timer T2 mode control bit
T2C0 Timer T2 Start/Stop control in timer
modes 1 and 2, T2 Underflow Interrupt Pending Flag in timer mode 3
T2PNDA Timer T2 Interrupt Pending Flag (Autoreload
RA in mode 1, T2 Underflow in mode 2, T2A
capture edge in mode 3)
T2ENA Timer T2 Interrupt Enable for Timer Underflow
or T2A Input capture edge
T2PNDB Timer T2 Interrupt Pending Flag for T2B cap-
ture edge
T2ENB Timer T2 Interrupt Enable for Timer Underflow
or T2B Input capture edge
Timers
The device contains a very versatile set of timers (T0, T1 and
T2). All timers and associated autoreload/capture registers
power up containing random data.
TIMER T0 (IDLE TIMER)
The device supports applications that require maintaining
real time and low power with the IDLE mode. This IDLE
mode support is furnished by the IDLE timer T0, which is a
16-bit timer. The Timer T0 runs continuously at the fixed rate
of the instruction cycle clock, t
write to the IDLE Timer T0, which is a count down timer.
The Timer T0 supports the following functions:
Exit out of the Idle Mode (See Idle Mode description)
•
WATCHDOG logic (See WATCHDOG description)
•
Start up delay out of the HALT mode
•
Figure 8
is a functional block diagram showing the structure
of the IDLE Timer and its associated interrupt logic.
Bits 11 through 15 of the ITMR register can be selected for
triggering the IDLE Timer interrupt. Each time the selected
bit underflows (every 4k, 8k, 16k, 32k or 64k instruction
cycles), the IDLE Timer interrupt pending bit T0PND is set,
thus generating an interrupt (if enabled), and bit 6 of the Port
G data register is reset, thus causing an exit from the IDLE
mode if the device is in that mode.
. The user cannot read or
c
In order for an interrupt to be generated, the IDLE Timer interrupt enable bit T0EN must be set, and the GIE (Global Interrupt Enable) bit must also be set. The T0PND flag and
T0EN bit are bits 5 and 4 of the ICNTRL register, respectively.The interrupt can be used for any purpose. Typically,it
is used to perform a task upon exit from the IDLE mode. For
more information on the IDLE mode, refer to the Power Save
Modes section.
DS012837-9
FIGURE 8. Functional Block Diagram for Idle Timer T0
The Idle Timer period is selected by bits 0–2 of the ITMR
register Bits 3–7 of the ITMR Register are reserved and
should not be used as software flags.
ITMR Register (Address X’0xCF)
Reserved ITSEL2 ITSEL1 ITSLE0
Bit 7 Bit 0
TABLE 2. Idle Timer Window Length
ITSEL2 ITSEL1 ITSEL0 Idle Timer Period
(Instruction Cycles)
0 0 0 4,096
0 0 1 8,192
0 1 0 16,384
0 1 1 32,768
1 X X 65,536
The ITMR register is cleared on Reset and the Idle Timer period is reset to 4,096 instruction cycles.
Any time the IDLE Timer period is changed there is the possibility of generating a spurious IDLE Timer interrupt by setting the T0PND bit. The user is advised to disable IDLE
Timer interrupts prior to changing the value of the ITSEL bits
of the ITMR Register and then clear theT0PND bit before attempting to synchronize operation to the IDLE Timer.
TIMER T1 and TIMER T2
The device has a set of three powerful timer/counter blocks,
T1 and T2. The associated features and functioning of a
timer block are described by referring to the timer block Tx.
Since the three timer blocks, T1 and T2 are identical, all
comments are equally applicable to either of the three timer
blocks.
Each timer block consists of a 16-bit timer, Tx, and two supporting 16-bit autoreload/capture registers, RxA and RxB.
Each timer block has two pins associated with it, TxA and
www.national.com15
Page 16

Timers (Continued)
TxB. The pin TxA supports I/O required by the timer block,
while the pin TxB is an input to the timer block. The powerful
and flexible timer block allows the device to easily perform all
timer functions with minimal software overhead. The timer
block has three operating modes: Processor Independent
PWM mode, External Event Counter mode, and Input Capture mode.
The control bits TxC3,TxC2, and TxC1 allow selection of the
different modes of operation.
Mode 1. Processor Independent PWM Mode
As the name suggests, this mode allows the device to generate a PWM signal with very minimal user intervention.
The user only has to define the parameters of the PWM signal (ON time and OFF time).Once begun, the timer block will
continuously generate the PWM signal completely independent of the microcontroller. The user software services the
timer block only when the PWM parameters require updating.
In this mode the timer Tx counts down at a fixed rate of t
Upon every underflow the timer is alternately reloaded with
the contents of supporting registers, RxA and RxB. The very
first underflow of the timer causes the timer to reload from
the register RxA. Subsequent underflows cause the timer to
be reloaded from the registers alternately beginning with the
register RxB.
The Tx Timer control bits, TxC3, TxC2 and TxC1 set up the
timer for PWM mode operation.
Figure 9
shows a block diagram of the timer in PWM mode.
per PWM period on either the rising or falling edge of the
PWM output. Alternatively, the user may choose to interrupt
on both edges of the PWM output.
Mode 2. External Event Counter Mode
This mode is quite similar to the processor independent
PWM mode described above. The main difference is that the
timer,Tx, is clocked by the input signal from theTxA pin. The
Tx timer control bits, TxC3, TxC2 andTxC1 allow the timer to
be clocked either on a positive or negative edge from the
TxA pin. Underflows from the timer are latched into the TxPNDA pending flag. Setting the TxENA control flag will cause
an interrupt when the timer underflows.
In this mode the input pin TxB can be used as an independent positive edge sensitive interrupt input if the TxENB control flag is set. The occurrence of the positive edge on the
TxB input pin is latched to the TxPNDB flag.
Figure 10
shows a block diagram of the timer in External
Event Counter mode.
.
c
DS012837-10
FIGURE 9. Timer in PWM Mode
The underflows can be programmed to toggle the TxAoutput
pin. The underflows can also be programmed to generate interrupts.
Underflows from the timer are alternately latched into two
pending flags, TxPNDA and TxPNDB. The user must reset
these pending flags under software control. Two control enable flags, TxENA and TxENB, allow the interrupts from the
timer underflow to be enabled or disabled. Setting the timer
enable flag TxENA will cause an interrupt when a timer underflow causes the RxA register to be reloadedinto the timer.
Setting the timer enable flag TxENB will cause an interrupt
when a timer underflow causes the RxB register to be reloaded into the timer. Resetting the timer enable flags will
disable the associated interrupts.
Either or both of the timer underflow interrupts may be enabled. This gives the user the flexibility of interrupting once
Note: The PWM output is not available in this mode since the TxA pin is
being used as the counter input clock.
DS012837-11
FIGURE 10. Timer in External Event Counter Mode
Mode 3. Input Capture Mode
The device can precisely measure external frequencies or
time external events by placing the timer block, Tx, in the input capture mode.
In this mode, the timer Tx is constantly running at the fixed t
rate. The two registers, RxA and RxB, act as capture registers. Each register acts inconjunction with a pin. The register
RxAacts in conjunction with the TxApin and the register RxB
acts in conjunction with the TxB pin.
The timer value gets copied over into the register when a
trigger event occurs on its corresponding pin. Control bits,
TxC3, TxC2 and TxC1, allow the trigger events to be specified either as a positive or a negative edge. The trigger condition for each input pin can be specified independently.
The trigger conditions can also be programmed to generate
interrupts. The occurrence of the specified trigger condition
on the TxA and TxB pins will be respectively latched into the
pending flags, TxPNDA and TxPNDB. The control flag
TxENA allows the interrupt on TxA to be either enabled or
disabled. Setting the TxENA flag enables interrupts to be
generated when the selected trigger condition occurs on the
TxA pin. Similarly, the flag TxENB controls the interrupts
from the TxB pin.
Underflows from the timer can also be programmed to generate interrupts. Underflows are latched into the timer TxC0
pending flag (the TxC0 control bit serves as the timer underflow interrupt pending flag in the Input Capture mode). Con-
c
www.national.com 16
Page 17

Timers (Continued)
sequently, the TxC0 control bit should be reset when entering the Input Capture mode. The timer underflow interrupt is
enabled with the TxENA control flag. When a TxA interrupt
occurs in the Input Capture mode, the user must check both
whether a TxA input capture or a timer underflow (or both)
caused the interrupt.
FIGURE 11. Timer in Input Capture Mode
TIMER CONTROL FLAGS
The control bits and their functions are summarized below.
TxC3 Timer mode control
TxC2 Timer mode control
TxC1 Timer mode control
TxC0 Timer Start/Stop control in Modes 1 and 2 (Pro-
cessor Independent PWM and External Event
Counter), where 1 = Start, 0 = Stop
Timer Underflow Interrupt Pending Flag in
Mode 3 (Input Capture)
TxPNDA Timer Interrupt Pending Flag
TxENA Timer Interrupt Enable Flag
1 = Timer Interrupt Enabled
0 = Timer Interrupt Disabled
TxPNDB Timer Interrupt Pending Flag
TxENB Timer Interrupt Enable Flag
1 = Timer Interrupt Enabled
0 = Timer Interrupt Disabled
Figure 11
ture mode.
shows a block diagram of the timer in Input Cap-
DS012837-12
www.national.com17
Page 18

Timers (Continued)
The timer mode control bits (TxC3, TxC2 and TxC1) are detailed below:
Mode TxC3 TxC2 TxC1 Description
Interrupt A
Source
1 0 1 PWM: TxA Toggle Autoreload RA Autoreload RB t
1
1 0 0 PWM: No TxA
Autoreload RA Autoreload RB
Toggle
0 0 0 External Event
2
0 0 1 External Event
Counter
Counter
Timer
Underflow
Timer
Underflow
Pos. TxB Edge Pos. TxA
Pos. TxB Edge Pos. TxA
0 1 0 Captures: Pos. TxA Edge Pos. TxB Edge t
TxA Pos. Edge or Timer
TxB Pos. Edge Underflow
1 1 0 Captures: Pos. TxA Neg. TxB t
TxA Pos. Edge Edge or Timer Edge
3
0 1 1 Captures: Neg. TxA Neg. TxB t
TxB Neg. Edge Underflow
TxA Neg. Edge Edge or Timer Edge
TxB Neg. Edge Underflow
1 1 1 Captures: Neg. TxA Neg. TxB t
TxA Neg. Edge Edge or Timer Edge
TxB Neg. Edge Underflow
Power Save Modes
The device offer the user two power save modes of operation: HALT and IDLE. In the HALT mode, all microcontroller
activities are stopped. In the IDLE mode, the on-board oscillator circuitry and timer T0 are active but all other microcontroller activities are stopped. In either mode, all on-board
RAM, registers, I/O states, and timers (with the exception of
T0) are unaltered.
HALT MODE
The device is placed in the HALTmode by writing a ’’1” to the
HALT flag (G7 data bit). All microcontroller activities, including the clock, and timers, are stopped. In the HALT mode,
the power requirements of the device are minimal and the
applied voltage (V
without altering the state of the machine.
) may be decreased to Vr (Vr = 2.0V)
CC
CAN HALT/IDLE mode:
In order to reduce the device overall current consumption in
HALT/IDLE mode a two step power save mechanism is
implemented on the device:
Step 1: Disable main receive comparator. This is done by
resetting both the TxEN0 and TxEN1 bits in the
CBUS register. Note: These bits should always be
reset before entering HALT/IDLE mode to allow
proper resynchronization to the CAN bus after exiting HALT/IDLE mode.
Step 2: Disable the CAN wake-up comparators, this is
done by resetting bit 7 in the port-m wakeup enable register (MWKEN) a transition on the CAN
bus will then not wake the device up.
Note: If both the main receive comparator and the wake-up comparator are
disabled the on chip CAN voltage reference is also disabled. The CAN-
output is then High-Z
V
REF
The following table shows the two CAN power save modes and the active CAN transceiver blocks:
Interrupt B
Source
Timer
Counts On
C
t
C
Edge
Edge
C
C
C
C
Step 1 Step 2 Main-Comp Wake-Up-Comp CAN-V
0 0 on on on V
0 1 on off on V
1 0 off on on V
1 1 off off off High-Z
The device supports two different ways of exiting the HALT
mode. The first method of exiting the HALTmode is with the
Multi-Input Wakeup feature on the L & M port. The second
method of exiting the HALT mode is by pulling the RESET
pin low.
Since a crystal or ceramic resonator may be selected as the
oscillator, the Wakeup signal is not allowed to start the chip
www.national.com 18
running immediately since crystal oscillators and ceramic
resonators have a delayed start up time to reach full amplitude and frequency stability. The IDLE timer is used to generate a fixed delay to ensure that the oscillator has indeed
stabilized before allowing instruction execution. In this case,
upon detecting a valid Wakeup signal, only the oscillator circuitry is enabled. The IDLE timer is loaded with a value of
REF
V
Pin
REF
/2
CC
/2
CC
/2
CC
Page 19

Power Save Modes (Continued)
256 and is clocked with the t
clock is derived by dividing theoscillator clock down by a factor of 10. The Schmitt trigger following the CKI inverter on
the chip ensures that the IDLEtimer is clocked only when the
oscillator has a sufficiently large amplitude to meet the
Schmitt trigger specifications. This Schmitt trigger is not part
of the oscillator closed loop. The start-up time-out from the
IDLE timer enables the clock signals to be routed to the rest
of the chip.
The device has two mask options associated with the HALT
mode. The first mask option enablesthe HALTmode feature,
while the second mask option disables the HALTmode. With
the HALT mode enable mask option, the device will enter
and exit the HALT mode as described above. With the HALT
disable mask option, the device cannot be placed in the
HALTmode (writing a “1” to the HALT flag will have to effect).
IDLE MODE
The device is placed in the IDLE mode by writing a “1” to the
IDLE flag (G6 data bit). In this mode, all activity, except the
associated on-board oscillator circuitry, ad the IDLE Timer
T0, is stopped. The power supply requirements of the microcontroller in this mode of operation are typically around 30
of normal power requirement of the microcontroller.
As with the HALT mode, the device can be returned to normal operation with areset, or with a Multi-Input Wakeup from
the Port L or CAN Interface. Alternately, the microcontroller
resumes normal operation from the IDLE mode when the
thirteenth bit (representing 4.096 ms at internal clock frequency of 1 MHz, t
c
This toggle condition of the thirteenth bit of the IDLE Timer
T0 is latched into the T0PND pending flag.
The user has the option of being interrupted with a transition
on the thirteenth bit of the IDLE Timer T0. The interrupt can
be enabled or disabled via the T0EN control bit. Setting the
T0EN flag enables the interrupt and vice versa.
The user can enter the IDLE mode with the Timer T0 interrupt enabled. In this case, when the T0PND bit gets set, the
device will first execute the Timer T0 interrupt service routine
and then return to the instruciton following the “Enter Idle
Mode” instruction.
Alternatively, the user can enter the IDLE mode with the
IDLE Timer T0 interrupt disabled. In this case, the device will
resume normal operation with the instruction immediately
following the “Enter IDLE Mode” instruction.
Note: It is necessary to program two NOP instructions following both the set
HALT mode and set IDLE mode instructions. These NOP instructions
are necessary to allow clock resynchronization following the HALT or
IDLE modes.
instruction cycle clock. The t
c
= 1 µs) of the IDLE Timer toggles.
Multi-Input Wakeup
The Multi-Input Wakeup feature is used to return (wakeup)
c
the device from either the HALT or IDLE modes. Alternately,
the Multi-Input Wakeup/Interrupt feature may also be used to
generate up to 7 edge selectable external interrupts.
Note: The following description is for both the Port L and the M port. When
the document refers to the registers WKEGD, WKEN or WKPND, the
user will have to put either M (for M port) or L (for port) in front of the
register, i.e., LWKEN (Port L WKEN), MWKEN (Port M WKEN).
Figures 12, 13
microcontroller.The Multi-Input Wakeupfeature utilizes the L
Port. The user selects which particular Port L bit (or combination of Port L bits) will cause the device to exit the HALT or
IDLE modes. The selection is done through the Reg: WKEN.
The Reg: WKEN is an 8-bit read/write register, which contains a control bit for every Port L bit. Setting a particular
WKEN bit enables a Wakeupfrom the associated Port L pin.
The user can select whether the trigger condition on the selected Port L pin is going to be either a positive edge (low to
high transition) or a negative edge (high to low transition).
This selection is made via the Reg: WKEDG, which is an
8-bit control register with a bit assigned to each Port L pin.
Setting the control bit will select the trigger condition to be a
%
negative edge on that particular Port L pin. Resetting the bit
selects the trigger condition to be a positive edge. Changing
an edge select entails several steps in order to avoid a
pseudo Wakeup condition as a result of the edge change.
First, the associated WKEN bit should be reset, followed by
the edge select change in WKEDG. Next, the associated
WKPND bit should be cleared, followed by the associated
WKEN bit being re-enabled.
An example may serve to clarify this procedure. Suppose we
wish to change the edge select from positive (low going high)
to negative (high going low) for Port L bit 5, where bit 5 has
previously been enabled for an input interrupt. The program
would be as follows:
RBIT 5, WKEN ; Disable MIWU
SBIT 5, WKEDG ; Change edge polarity
RBIT 5, WKPND ; Reset pending flag
SBIT 5, WKEN ; Enable MIWU
If the Port L bits have been used as outputs and then
changed to inputs with Multi-InputWakeup/Interrupt, a safety
procedure should also be followed to avoid inherited pseudo
wakeup conditions. After the selected Port L bits have been
changed from output to input but before the associated
WKEN bits are enabled, the associated edge select bits in
WKEDG should be set or reset for the desired edge selects,
followed by the assoicated WKPND bits being cleared.
shows the Multi-Input Wakeup logic for the
www.national.com19
Page 20

Multi-Input Wakeup (Continued)
FIGURE 12. Port M Multi-Input Wake-up Logic
This same procedure should be used following reset, since
the Port L inputs are left floating as a result of reset. The occurrence of the selected trigger condition for Multi-Input
Wakeup is latched to a pending register called WKPND. The
respective bits of the WKPND register will be set on the occurrence of the selected trigger edge on the corresponding
Port L and Port M pin. The user has the responsibility of
clearing these pending flags. Since WKPND is a pending
register for the occurrence of selected wakeup conditions,
the device will not enter the HALT mode if any wakeup bit is
both enabled and pending. Consequently, the user has the
responsibility of clearing the pending flags before attempting
to enter the HALT mode.
The WKEN, WKPND and WKEDG are all read/write registers, and are cleared at reset.
PORTS L AND PORT M INTERRUPTS
Ports L and M provides the user with additional fifteen fully
selectable, edge sensitive interrupts which are all vectored
into the same service subroutine.
The interrupt from Ports L and M shares logic with the wake
up circuitry. The register WKEN allows interrupts from Port L
to be individually enabled or disabled. The registers LWKEN
and MWKEN specifies the trigger condition to be either a
positive or a negative edge. Finally, the registers LWKEN
and MWKEN latches in the pending trigger conditions.
The GIE (global interrupt enable) bit enables the interrupt
function. A control flag, LPEN, functions as a global interrupt
enable for Port Linterrupts. Setting the LPEN flag will enable
DS012837-13
interrupts and vice versa. A separate global pending flag is
not needed since the registers LWKEN and MWKEN are adequate.
Since Ports L and M are also used for waking the device out
of the HALT or IDLE modes, the user can elect to exit the
HALT or IDLE modes either with or without the interrupt enabled. If he elects todisable the interrupt, then thedevice will
restart execution from the instruction immediately following
the instruction that placed the microcontroller in the HALT or
IDLE modes. In the other case, the device will first execute
the interrupt service routine and then revert to normal operation.
The Wakeup signal will not start the chip running immediately since crystal oscillators orceramic resonators have a finite start up time. The IDLE Timer (T0) generates a fixed delay to ensure that the oscillator has indeed stabilized before
allowing the device to execute instructions. In this case,
upon detecting a valid Wakeup signal, only the oscillator circuitry and the IDLE Timer T0 are enabled.The IDLE Timer is
loaded with a value of 256 and is clocked from the t
tion cycle clock. The t
oscillator clock by a factor of 10. A Schmitt trigger following
clock is derived by dividing down the
c
instruc-
c
the CKI on-chip inverter ensures that the IDLE timer is
clocked only when the oscillator has a sufficiently large amplitude to meet the Schmitt trigger specifications. This
Schmitt trigger is not part of the oscillator closed loop. The
start-up time-out from the IDLE timer enables the clock signals to be routed to the rest of the chip.
www.national.com 20
Page 21

Multi-Input Wakeup (Continued)
FIGURE 13. Port L Multi-Input Wake-Up Logic
PORT M INTERRUPTS
Port M provides the user with seven fully selectable, edge
sensitive interrupts which are all vectored into the same service subroutine.
The interrupt from Port M shares logic with the wake up circuitry.The MWKEN register allows interrupts from Port M to
be individually enabled or disabled. The MWKEDG register
specifies the trigger condition to be either a positive or a
negative edge. The MWKPND register latches in the pending trigger conditions.
The LPEN control flag in the ICNTRL register functions as a
global interrupt enable for Port M interrupts. Setting the
LPEN flag enables interrupts. Note that the GIE bit in the
PSW register must also be set to enable these Port L interrupts.A global pending flag is not needed since each pin has
a corresponding pending flag in the MWKPND register.
Since Port M is also used for exiting the device from the
HALT or IDLE mode, the user can elect to exit the HALT or
IDLE mode either with or without the interrupt enabled. If the
user elects to disable the interrupt, then the device restarts
execution from the point at which it was stopped (first instruction cycle of the instruction following the enter HALT or
IDLE mode instruction). In theother case, the device finishes
the instruction which was being executed when the part was
stopped (the NOP(Note 26) instruction following the enter
HALT or IDLE mode instruction), and then branches to the
interrupt service routine. The device then reverts to normal
operation.
Note 26: Theuser must place two NOPs after an enter HALT or IDLE mode
instruction.
To prevent erroneous clearing of the SPI receive FIFO when
entering HALT/IDLE mode, the user needs to enable the
MIWU on port M3. (SS) by setting bit 3 in the MWKEN register.
DS012837-14
CAN RECEIVE WAKEUP
The CAN Receive Wakeup source can be enabled or disabled. There is no specific enable bit for the CAN Wakeup
feature. Although the wakeup feature on pins L0..17 and
M0..M7 can be programmed to generate an interrupt (Port L
or Port M interrupt), nointerrupt is generated upon aCAN receive wakeup condition. The CAN block has it’s own, dedicated receiver interrupt upon receive buffer full (see CAN
Section).
CAN Wake-Up:
The CAN interface can be programmed to wake the device
from HALT/IDLE mode. This is done by setting bit 7 in the
Port M wake-up enable register (MWKEN). A transition on
the bus will cause the bit 7 of the Port M wake-up pending
(MWKPND) to be set and thereby waking up the device. The
frame on the CAN bus will be lost. The MWEDG (m port
wake-up edge) register bit 7 can be programmed high or low
(high will wake-up on the first falling edge on Rx0).
Resetting bit 7 in the MWKEN will disable the CAN wake-up.
The following sequence should be executed before entering
HALT/IDLE mode:
RBIT 7, MWKPND ;clear CAN wake-up pending
LD A, CBUS
AND A, #0CF ;resetTxEN0 and TxEN1
X A, CBUS ;disable main receive
;comparator
After the device wake-up, the CBUS bits TxEN0 and/or
TxEN1 need be set to allow synchronization on the bus and
to enable transmission/reception of CAN frames.
CAN Block Description *
This device contains a CAN serial bus interface as described
in the CAN Specification Rev. 2.0 part B.
*Patents Pending.
www.national.com21
Page 22

CAN Interface Block
This device supports applications which require a low speed
CAN interface. It is designed to be programmed with two
transmit and two receive registers. The user’s program may
check the status bytes in order to get information of the bus
state and the received or transmitted messages. The device
has the capability to generate an interrupt as soon as one
byte has been transmitted or received. Care must be taken if
more than two bytes in a message frame are to be
transmitted/received. In this case the user’s program must
poll the transmit buffer empty (TBE)/receive buffer full (RBF)
bits or enable their respective interrupts and perform a data
exchange between the user data and the Tx/Rx registers.
Fully automatic transmission on error is supported for messages not longer than two bytes. Messages which are longer
than two bytes have to be processed by software.
The interface is compatible with CAN Specification 2.0 part
B, without the capability to receive/transmit extended
frames. Extended frames on the bus are checked and acknowledged according to the CAN specification.
The maximum bus speed achievable with the CAN interface
is a function of crystal frequency, message length and software overhead. The device can support a bus speed of up to
1 Mbit/s with a 10 MHz oscillator and 2 byte messages. The
1 Mbit/s bus speed refers to the rate at which protocol and
data bits are transferred on the bus. Longer messages require slower bus speeds due to the time required for software intervention between data bytes. The device will support a maximum of 125k bit/s with eight byte messages and
a 10 MHz oscillator.
FIGURE 14. CAN Interface Block Diagram
www.national.com 22
DS012837-16
Page 23

Functional Block Description of
the CAN Interface
Interface Management Logic (IML)
The IML executes the CPU’s transmission and reception
commands and controls the data transfer between CPU,
Rx/Tx and CAN registers. It provides the CAN Interface with
Rx/Tx data from the memory mapped Register Block. It also
sets and resets the CAN status information and generates
interrupts to the CPU.
Bit Stream Processor (BSP)
The BSP is a sequencer controlling the data stream between
The Interface Management Logic (parallel data) and the bus
line (serial data). It controls the transceive logic with regard
to reception and arbitration, and creates error signals according to the bus specification.
Transceive Logic (TCL)
The TCL is a state machine which incorporates the bit stuff
logic and controls the output drivers, CRC logic and the
Rx/Tx shift registers. It also controls the synchronization to
the bus with the CAN clock signal generated by the BTL.
Error Management Logic (EML)
The EML is responsible for the fault confinement of the CAN
protocol. It is also responsible for changing the error
counters, setting the appropriate error flag bits and interrupts
and changing the error status (passive, active and bus off).
Cyclic Redundancy Check (CRC)
Generator and Register
The CRC Generator consists of a 15-bit shift register and the
logic required to generate the checksum of the destuffed bitstream. It informs the EML about the result of a receiver
checksum.
The checksum is generated by the polynomial:
Receive/Transmit (Rx/Tx) Registers
The Rx/Tx registers are 8-bit shift registers controlled by the
TCL and the BSP. They are loaded or read by the Interface
Management Logic, which holds the data to be transmitted
or the data that was received.
15
14
10
8
7
4
χ
+
χ
+
χ
+
χ
+
χ
3
+
χ
+
χ
−1
Bit Time Logic (BTL)
The bit time logic divider divides the CKI input clock by the
value defined in the CAN prescaler (CSCAL) and bus timing
register (CTIM). The resultig bit time (tcan) can be computed
by the formula:
Where
divider
is the value of the clock prescaler,PSis the
programmable value of phase segment 1 and 2 (1..8) and
PPS
the programmed value of the propagation segment
(1..8) (located in CTIM).
Bus Timing Considerations
The internal architecture of the CAN interface has been optimized to allow fast software response times within messages of more than two data bytes. The TBE (Transmit
Buffer Empty) bit is set on the last bit of odd data bytes when
CAN internal sample points are high.
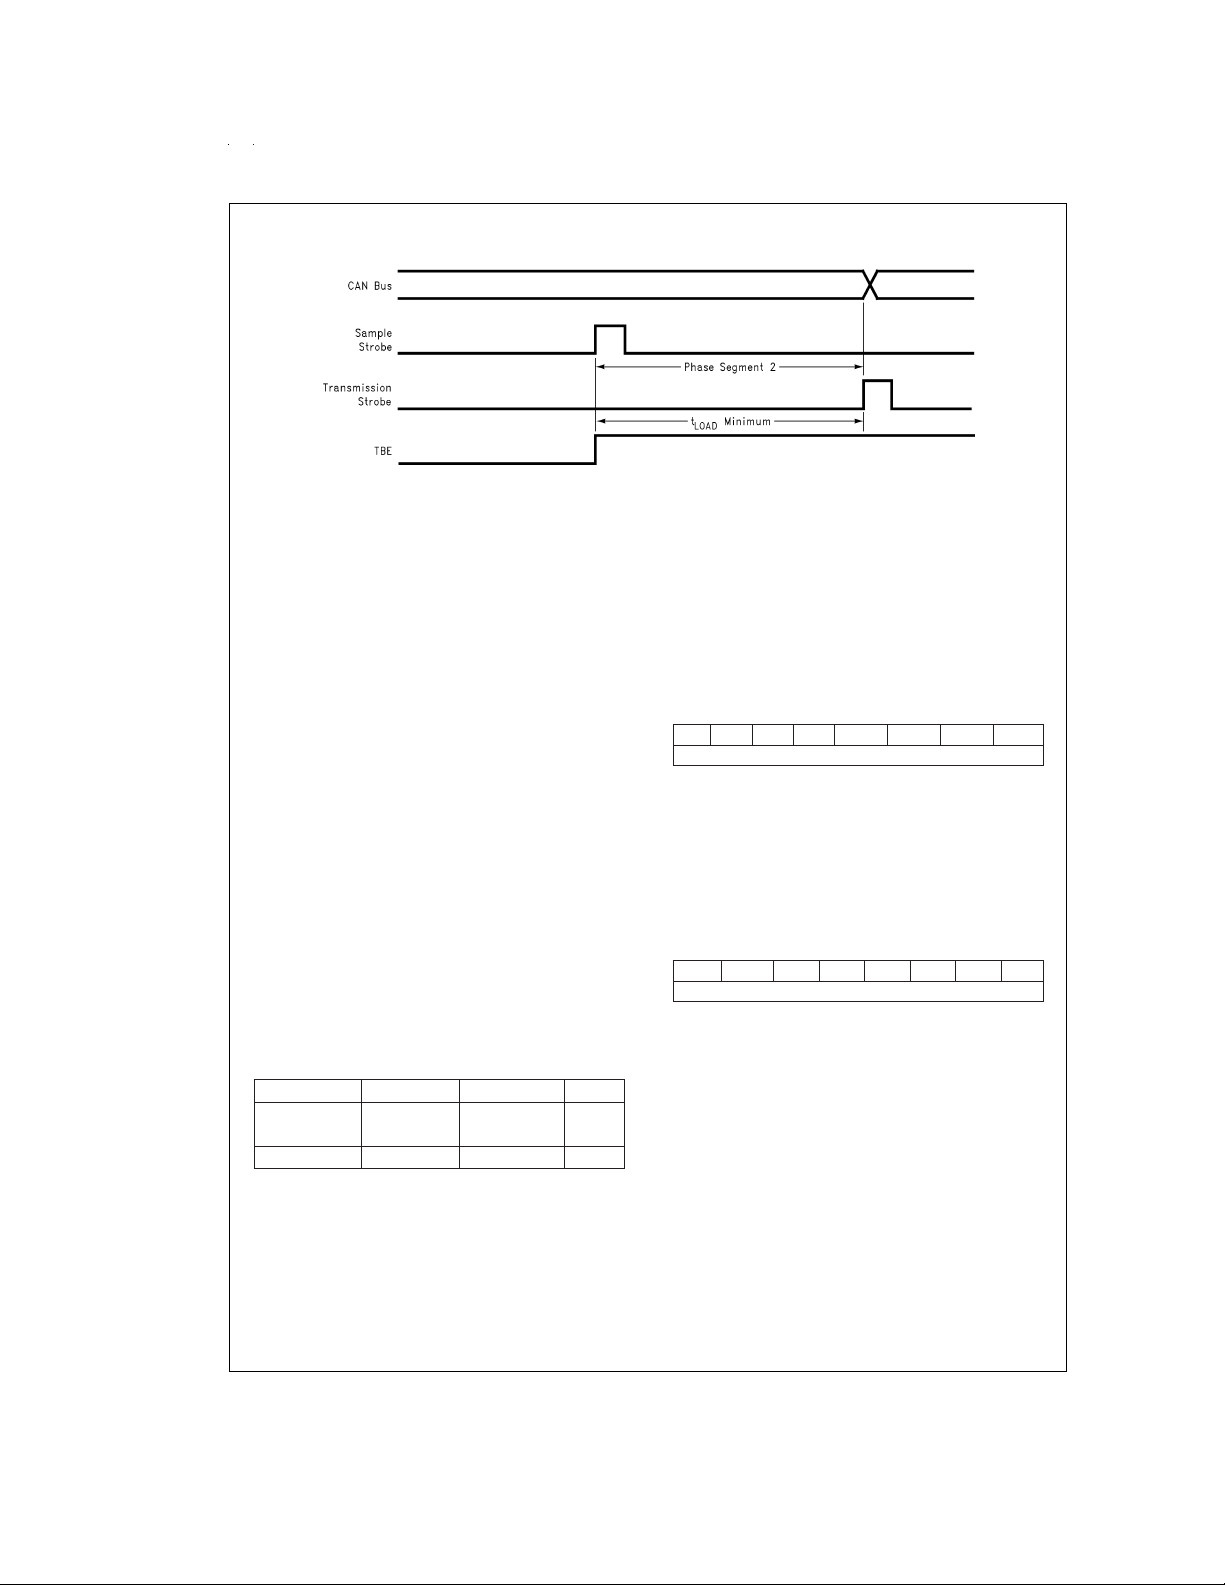
It is the user’s responsibility to ensure that the time between
setting TBE and a reload of TxD2 is longer than the length of
phase segment 2 as indicated in the following equation:
Table 3
shows examples of the minimum required t
different CSCAL settings based on a clock frequency of
LOAD
for
10 MHz. Lower clock speeds require recalculation of the
CAN bit rate and the mimimum t
TABLE 3. CAN Timing (CKI = 10 MHz, t
PS CSCAL CAN Bit Rate (kbit/s)
LOAD
.
= 1 µs)
c
Minimum
t
(µs)
LOAD
4 3 250 2.0
4 9 100 5.0
4 15 62 8.0
4 24 40 12.5
439 25 20
499 10 50
4 199 5 100
Figure 16
FIGURE 15. Bit Rate Generation
illustrates the minimum time required for t
LOAD
DS012837-17
.
www.national.com23
Page 24
Functional Block Description of the CAN Interface (Continued)
FIGURE 16. TBE Timing
In the case of an interrupt driven CAN interface, the calculation of the actual t
time would be done as follows:
LOAD
INT: ;Interrupt latency = 7tc=7µs
PUSH A ; 3tc=3µs
LD A,B;2tc=2µs
PUSH A ; 3tc=3µs
VIS ;5tc=5µs
CANTX: ;20tc = µs to this point
•
;additional time for instructions
;which check
•
;status prior to reloading the
;transmit data
•
;registers with subsequent data
;bytes.
LD TXD2,DATA
•
•
•
Interrupt driven programs use more time than programs
which poll the TBE flag, however programs which operate at
lower baud rates (which are more likely to be sensitive to this
issue) have more time for interrupt response.
Output Drivers/Input Comparators
The output drivers/input comparators are the physical interface to the bus. Control bits are provided to TRI-STATE the
output drivers.
A dominant bit on the bus is represented as a “0” in the data
registers and a recessive bit on the bus is represented as a
“1” in the data registers.
TABLE 4. Bus Level Definition
Bus Level Pin Tx0 Pin Tx1 Data
“dominant” drive low dirve high 0
(GND) (V
)
CC
“recessive” TRI-STATE TRI-STATE 1
Register Block
The register block consists of fifteen 8-bit registers which are
described in more detail in the following paragraphs.
Note: The contents of the receiver related registers RxD1, RxD2, RDLC,
RIDH and RTSTAT are only changed if a received frame passes the
acceptance filter or the Receive Identifier Acceptance Filter bit (RIAF)
is set to accept all received messages.
TRANSMIT DATA REGISTER 1 (TXD1)(Address X’00A0)
The Transmit Data Register 1 contains the first data byte to
be transmitted within a frame and then the successive odd
byte numbers (i.e., bytes number 1,3,..,7).
TRANSMIT DATA REGISTER 2 (TXD2)(Address X’00A1)
The Transit Data Register 2 contains the second data byte to
be transmitted within a frame and then the successive even
byte numbers (i.e., bytes number 2,4,..,8).
TRANSMIT DATA LENGTH CODE AND IDENTIFIER
LOW REGISTER (TDLC)(Address X’00A2)
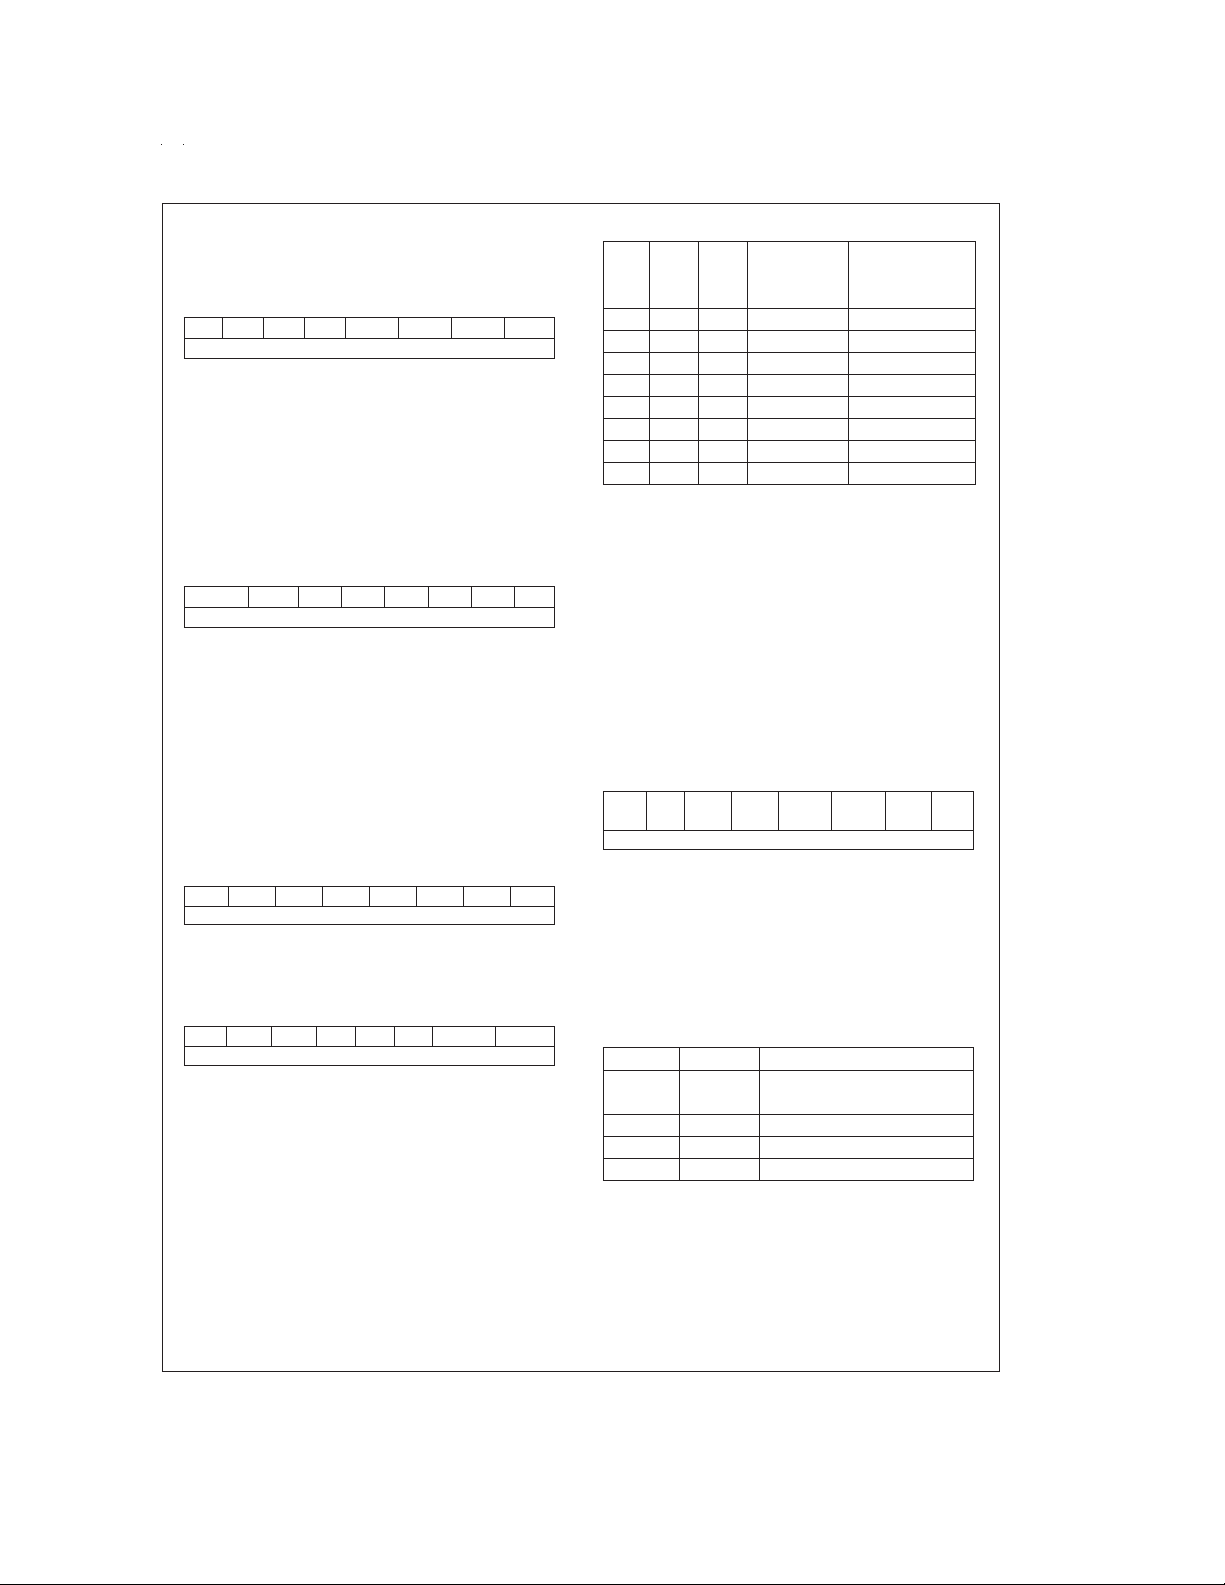
TID3 TID2 TID1 TID0 TDLC3 TDLC2 TDLC1 TDLC0
Bit 7 Bit 0
This register is read/write.
TID3..TIDO Transmit Identifier Bits 3..0 (lower 4 bits)
The transmit identifier is composed of eleven bits in total, bits
3 to 0 of the TID are stored in bits 7 to 4 of this register.
TDLC3..TDLC0 Transmit Data Length Code
These bits determine the number of data bytes to be trans-
mitted within a frame. The CAN specification allows a maximum of eight data bytes in any message.
TRANSMIT IDENTIFIER HIGH (TID)(Address X’00A3)
TRTR TID10 TID9 TID8 TID7 TID6 TID5 TID4
Bit 7 Bit 0
This register is read/write.
TRTR Transmit Remote Frame Request
This bit is set if the frame to be transmitted is a remote frame
request.
TID10..TID4 Transmit Identifier Bits 10 .. 4 (higher 7 bits)
Bits TID10..TID4 are the upper 7 bits of the 11 bit transmit
identifier.
RECEIVER DATA REGISTER 1 (RXD1)(Address X’00A4)
The Receive Data Register 1 (RXD1) contains the first data
byte received in a frame and then successive odd byte numbers (i.e., bytes 1, 3,..7). This register is read-only.
RECEIVE DATA REGISTER 2 (RXD2)(Address X’00A5)
The Receive Data Register 2 (RXD2) contains the second
data byte received in a frame and then successive even byte
numbers (i.e., bytes 2,4,..,8). This register is read-only.
DS012837-18
www.national.com 24
Page 25
Functional Block Description of
the CAN Interface
REGISTER DATA LENGTH CODE AND IDENTIFIERLOW
REGISTER (RIDL)(Address X’00A6)
RID3 RID2 RID1 RID0 RDLC3 RDLC2 RDLC1 RDLC0
Bit 7 Bit 0
This register is read only.
RID3..RID0 Receive Identifier bits (lower four bits)
The RID3..RID0 bits are the lower four bits of the eleven bit
long Receive Identifier. Any received message that matches
the upper 7 bits of the Receive Identifier (RID10..RID4) is accepted if the Receive IdentifierAcceptance Filter (RIAF) bitis
set to zero.
RDLC3..RDLC0 Receive Data Length Code bits
The RDLC3..RDLC0 bits determine the number of data
bytes within a received frame.
RECEIVE IDENTIFIER HIGH (RID)(Address X’00A7)
Reserved RID10 RID9 RID8 RID7 RID6 RID5 RID4
Bit 7 Bit 0
This register is read/write.
Bit 7 is reserved and should be zero.
RID10..RID4 Receive Identifier bits (upper bits)
The RID10...RID4 bits are the upper 7 bits of the eleven bit
long Receive Identifier. If the Receive Identifier Acceptance
Filter (RIAF) bit (see CBUS register) is set to zero, bits 4 to
10 of the received identifier are compared with the mask bits
of RID4..RID10. If the corresponding bits match, the message is accepted. If the RIAF bit is set to a one, the filter
function is disabled and all messages, independent of identifier, will be accepted.
CAN PRESCALER REGISTER (CSCAL)(Address
X’00A8)
CKS7 CKS6 CKS5 CKS4 CKS3 CKS2 CKS1 CKS0
Bit 7 Bit 0
This register is read/write.
CKS7..0 Prescaler divider select.
The resulting clock value is the CAN Prescaler clock.
CAN BUS TIMING REGISTER (CTIM) (Address X’00A9)
PPS2 PPS1 PPS0 PS2 PS1 PS0 Reserved Reserved
Bit 7 Bit 0
This register is read/write.
PPS2..PPS0 Propagation Segment, bits 2..0
The PPS2..PPS0 bits determine the length of the propaga-
tion delay in Prescaler clock cycles (PSC) per bit time. (For
a more detailed discussion of propagation delay and phase
segments, see SYNCHRONIZATION.)
PS2..PS0 Phase Segment 1, bits 2..0
The PS2..PS0 bits fix the number of Prescaler clock cycles
per bit time for phase segment 1 and phase segment 2. The
PS2..PS0 bits also set the synchronization Jump Width to a
value equal to the lesser of: 4 PSC, or the length of PS1/2
(Min: 4 l length of PS1/2).
Bits 1 and 0 are reserved and should be zero.
(Continued)
TABLE 5. Synchronization Jump Width
Length of Synchronization
PS2 PS1 PS0 Phase Jump Width
Segment
000 1t
001 2t
010 3t
011 4t
100 5t
101 6t
110 7t
111 8t
LENGTH OF TIME SEGMENTS (See
The Synchronization Segment is 1 CAN Prescaler clock
•
1
⁄
2
Figure 28
1t
2t
3t
4t
4t
4t
4t
4t
can
can
can
can
can
can
can
can
)
can
can
can
can
can
can
can
can
(PSC)
The Propagation Segment can be programmed (PPS) to
•
be 1,2...,8 PSC in length.
Phase Segment 1 and Phase Segment 2 are program-
•
mable (PS) to be 1,2,..,8 PSC long.
Note: (BTL settings at high speed; PSC = 0) Due to the on-chip delay from
the rx-pins through the receive comparator (worst case assumption: 3
clocks delay * 2 (devices on the bus)+1txdelay)the user needs to set
the sample point to (2*3 + 1) i.e., 7 CKI clocks to ensure correct communication on the bus under all circumstances. With prescaler settings
of 0 this is a given (i.e., no caution has to be applied).
Example: for 1 Mbit CTIM = b’10000100 (PSS = 5; PS1 = 2). Example
for 500 kbit CTIM = b’01011100 (PPS = 3; PS1 = 8). − all at 10 MHz
CKI and CSCAL = 0.
CAN BUS CONTROL REGISTER (CBUS) (00AA)
Re- RIAF TxEN1 TxEN0 RxREF1 RxREF0 Re- FMOD
served served
Bit 7 Bit 0
Reserved These bits are reserved and should be zero.
RIAF Receive identifier acceptance filter bit
If the RIAF bit is set to zero, bits 4 to 10 of the received iden-
tifier are compared with the mask bits of RID4..RID10 and if
the corresponding bits match, the message is accepted. If
the RIAF bit is set to a one, the filter function is disabled and
all messages independent of the identifier will be accepted.
TxEN0, TxEN1 TxD Output Driver Enable
TABLE 6. Output Drivers
TxEN1 TxEN0 Output
0 0 Tx0, Tx1 TRI-STATE, CAN
input comparator disabled
0 1 Tx0 enabled
1 0 Tx1 enabled
1 1 Tx0 and Tx1 enabled
Bus synchronization of the device is done in the following
way:
If the output was disabled (TxEN1, TxEN0 = “0”) and either
TxEN1 or TxEN0, or both are setto 1, the device will not start
transmission or reception of a frame until eleven consecutive
“recessive” bits have been received. Resetting the TxEN1
and TxEN0 bits will disable the output drivers and the CAN
input comparator. All other CAN related registers and flags
will be unaffected. It is recommended that the user reset the
TxEN1 and TxEN0 bits before switching the device into the
www.national.com25
Page 26
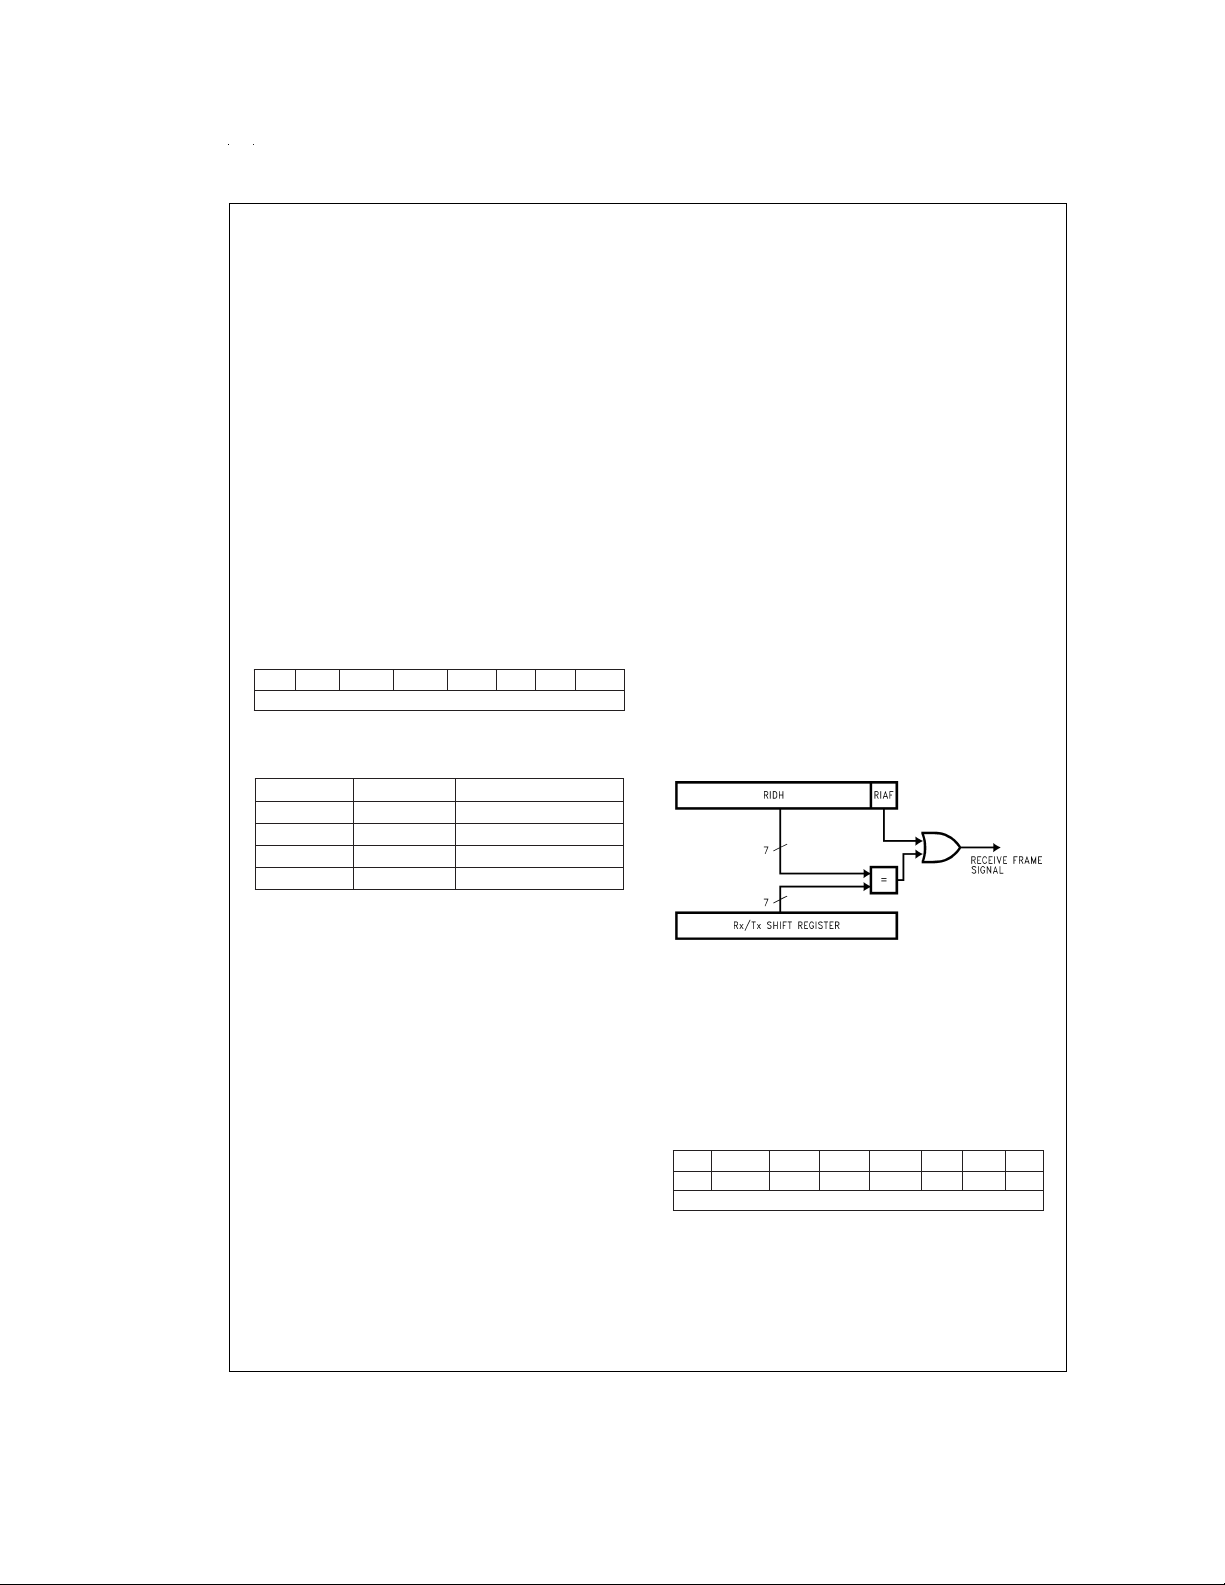
Functional Block Description of
the CAN Interface
HALTmode (the CAN receive wakeup will still work) in order
to reduce current consumption and to assure a proper resychronization to the bus after exiting the HALT mode.
Note: A “bus off” condition will also cause Tx0 and Tx1 to be at TRI-STATE
(independent of the values of the TxEN1 and TxEN0 bits).
RXREF1 Reference voltage applied to Rx1 if bit is set
RXREF0 Reference voltage applied to Rx0 if bit is set
FMOD Fault Confinement Mode select
Setting the FMOD bit to “0” (default after power on reset) will
select the Standard Fault Confinement mode. In this mode
the device goes from “bus off” to “error active” after monitoring 128*11recessive bits (includingbus idle) on the bus. This
mode has been implemented for compatibility with existing
solutions. Setting the FMOD bit to “1” will select the Enhanced Fault Confinement mode. In this mode the device
goes from “bus off” to “error active” after monitoring 128
“good” messages, as indicated by the reception of 11 consecutive “recessive” bits including the End of Frame,
whereas the standard mode may time out after 128 x 11 recessive bits (e.g., bus idle).
TRANSMIT CONTROL/STATUS (TCNTL) (00AB)
NS1 NS0 TERR RERR CEIE TIE RIE TXSS
Bit 7 Bit 0
NS1..NS0 Node Status, i.e., Error Status.
TABLE 7. Node Status
NS1 NS0 Output
0 0 Error active
0 1 Error passive
1 0 Bus off
1 1 Bus off
The Node Status bits are read only.
TERR Transmit Error
This bit is automatically set when an error occurs during the
transmission of a frame. TERR can be programmed to generate an interrupt by setting the Can Error Interrupt Enable
bit (CEIE). This bit must be cleared by the user’s software.
Note: This is used for messages for more than two bytes. If an error occurs
during the transmission of a frame with more than 2 data bytes, the user’s software has to handle the correct reloading of the data bytes to
the TxD registers for retransmission of the frame. For frames with 2 or
fewer data bytes the interface logic of this chip does an automatic retransmission. Regardless of the number of data bytes, the user’s software must reset this bit if CEIE is enabled. Otherwise a new interrupt
will be generated immediately after return from the interrupt service
routine.
RERR Receiver Error
This bit is automatically set when an error occurred during
the reception of a frame. RERR can be programmed to generate an interrupt by setting the Can Error Interrupt Enable
bit (CEIE). This bit has to be cleared by the user’s software.
CEIE CAN Error Interrupt Enable
If set by the user’s software, this bit enables the transmit and
receive error interrupts. The interrupt pending flags are
TERR and RERR. Resetting this bit with a pending error interrupt will inhibit the interrupt, but will not clear the cause of
the interrupt (RERR or TERR). If the bit is then set without
clearing the cause of the interrupt, the interrupt will reoccur.
(Continued)
TIE Transmit Interrupt Enable
If set by the user’s software, this bit enables the transmit in-
terrupt. (See TBE and TXPND.) Resetting this bit with a
pending transmit interrupt will inhibit the interrupt, but will not
clear the cause of the interrupt. If the bit is then set without
clearing the cause of the interrupt, the interrupt will reoccur.
RIE Receive Interrupt Enable
If set by the user’s software, this bit enables the receive in-
terrupt or a remote transmission request interrupt (see RBF,
RFV and RRTR). Resetting this bit with a pending receive interrupt will inhibit the interrupt, but will not clear the cause of
the interrupt. If the bit is then set without clearing the cause
of the interrupt, the interrupt will reoccur.
TXSS Transmission Start/Stop
This bit is set by the user’s software to initiate the transmis-
sion of a frame. Once this bit is set, a transmission is pending, as indicated by the TXPND flag being set.It can be reset
by software to cancel a pending transmission. Resetting the
TXSS bit will only cancel a transmission, if the transmission
of a frame hasn’t been started yet (bus idle), if arbitration has
been lost (receiving) or if an error occurs during transmission. If the device has already started transmission (won arbitration) the TXPND and TXSS flags will stay set until the
transmission is completed, even if the user’s software has
written zero to the TXSS bit. If one or more data bytes are to
be transmitted, care must be taken by the user, that the
Transmit Data Register(s) have been loaded before the
TXSS bit is set. TXSS will be cleared on three conditions
only: Successful completion of a transmitted message; successful cancellation of a pending transmision; Transition of
the CAN interface to the bus-off state.
DS012837-52
FIGURE 17. Acceptance Filter Block-Diagram
Writing a zero to the TXSS bit will request cancellation of a
pending transmission but TXSS will not be cleared until
completion of the operation. If an error occurs during transmission of a frame, the logic will check for cancellation requests prior to restarting transmission. If zero has been written to TXSS, retransmission will be canceled.
RECEIVE/TRANSMIT STATUS (RTSTAT) (Address
X’00AC)
TBE TXPND RRTR ROLD RORN RFV RCV RBF
10 000000
Bit 7 Bit 0
This register is read only.
TBE Transmit Buffer Empty
This bit is set as soon as the TxD2 register is copied into the
Rx/Tx shift register, i.e., the 1st data byte of each pair has
been transmitted. The TBE bit is automatically reset if the
TxD2 register is written (the user should write a dummy byte
to the TxD2 register when transmitting an odd number of
bytes of zero bytes). TBE can be programmed to generate
www.national.com 26
Page 27
Functional Block Description of
the CAN Interface
an interrupt by setting the TransmitInterrupt Enable bit (TIE).
When servicing the interrupt the user has to make sure that
TBE gets cleared by executing a WRITE instruction on the
TxD2 register, otherwise a new interrupt will be generated
immediately after return from the interrupt service routine.
The TBE bit is read only. It is set to 1 upon reset. TBE is also
set upon completion of transmission of a valid message.
TXPND Transmission Pending
This bit is set as soon as the Transmit Start/Stop (TXSS) bit
is set by the user. It will stay set until the frame was successfully transmitted, until the transmission wassuccessfully canceled by writing zero to the Transmission Start/Stop bit
(TXSS), or the device enters the bus-off state. Resetting the
TXSS bit will only cancel a transmission if the transmission
of a frame hasn’t been started yet (bus idle) or if arbitration
has been lost (receiving). If the device has already started
transmission (won arbitration) the TXPND flag will stay set
until the transmission is completed, even if the user’s software has requested cancellation of the message. If an error
occurs during transmission, a requested cancellation may
occur prior to the begining of retransmission.
RRTR Received Remote Transmission Request
This bit is set when the remote transmission request (RTR)
bit in a received frame was set. It is automatically reset
through a read of the RXD1 register.
To detect RRTR the user can either poll this flag or enable
the receive interrupt (the reception of a remote transmission
request will also cause an interrupt if the receive interrupt is
enabled). If the receive interrupt is enabled, the user should
check the RRTR flag in the service routine in order to distinguish between a RRTR interrupt anda RBF interrupt. It is the
responsibility of the user to clearthis bit by reading the RXD1
register, before the next frame is received.
ROLD Received Overload Frame
This bit is automatically set when an Overload Frame was
received on the bus. It is automatically reset through a read
of the Receive/Transmit Status register. It is the responsibility of the user to clear this bit by reading the Receive/
Transmit Status register, before the next frame is received.
RORN Receiver Overrun
This bit is automatically set on an overrun of the receive data
register, i.e., if the user’s program does not maintain the
RxDn registers when receiving a frame. It it automatically reset through a read of the Receive/Transmit Status register.It
is the responsibility of the user to clear this bit by reading the
Receive/Transmit Status register before the next frame is received.
RFV Received Frame Valid
This bit is set if the received frame is valid, i.e., after the pen-
ultimate bit of the End of Frame is received. It is automatically reset through a read of the Receive/Transmit Status
register. It is the responsibility of the user to clear this bit by
reading the receive/transmit status register (RTSTAT), before the next frame is received. RFV will cause a Receive Interrupt if enabled by RIE. The user should be careful to read
the last data byte (RxD1) of odd length messages (1, 3, 5 or
7 data bytes) on receipt of RFV. RFV is the only indication
that the last byte of the message has been received.
RCV Receive Mode
This bit is set after the data length code of a message that
passes the device’s acceptance filter has been received. It is
(Continued)
automatically reset after the CRC-delimiter of the same
frame has been received. It indicates to the user’s software
that arbitration is lost andthat data is coming in for thatnode.
RBF Receive Buffer Full
This bit is set if the second Rx data byte was received. It is
reset automatically, after the RxD1-Register has been read
by the software. RBF can be programmed to generate an interrupt by setting the Receive Interrupt Enable bit (RIE).
When servicing the interrupt, the user has to make sure that
RBF gets cleared by executing a LD instruction from the
RxD1 register, otherwise a new interrupt will be generated
immediately after return from the interrupt service routine.
The RBF bit is read only.
TRANSMIT ERROR COUNTER (TEC) (Address X’00AD)
TEC7 TEC6 TEC5 TEC4 TEC3 TEC2 TEC1 TEC0
Bit 7 Bit 0
This register is read/write.
For test purposes and to identify the node status, the trans-
mit error counter, an 8-bit error counter, is mapped into the
data memory. If the lower seven bits of the counter overflow,
i.e., TEC7 is set, the device is error passive.
CAUTION
To prevent interference with the CAN fault confinement, the
user must not write to the REC/TEC registers. Both counters
are automatically updated following the CAN specification.
RECEIVE ERROR COUNTER (REC) (00AE)
ROVL REC6 REC5 REC4 REC3 REC2 REC1 REC0
Bit 7 Bit 0
This register is read/write.
ROVL receive error counter overflow
For test purposes and to identify the node status the receive
error counter, a 7-bit error counter, is mapped into the data
memory. If the counter overflows the ROVL bit is set to indicate that the device is error passive and won’t transmit any
active error frames. If ROVL is set then the counter is frozen.
MESSAGE IDENTIFICATION
a. Transmitted Message
The user can select all 11Transmit Identifier Bits to transmit
any message whigh fulfills the CAN2.0, part B spec without
an extended identifier (see note below). Fully automatic retransmission is supported for messages no longer than 2
bytes.
b. Received Messages
The lower four bits of the Receive Identifier are don’t care,
i.e., the controller will receive allmessages that fit in that window (16 messages). The upper 7 bits can be defined by the
user in the Receive Identifier High Register to mask out
groups of messages. If the RIAF bit is set, all messages will
be received.
Note: The CAN interface tolerates the extended CAN frame format of 29
identifier bits and gives an acknowledgment. If an error occurs the receive error counter will be increased, and decreased if the frame is
valid.
BUS SYNCHRONIZATION DURING OPERATION
Resetting the TxEN1 and TxEN0 bits in Bus Control Register
will disable the output drivers and do a resynchronization to
the bus. All other CAN related registers and flags will be unaffected.
www.national.com27
Page 28
Functional Block Description of
the CAN Interface
Bus synchronization of the device is this case is done in the
following way:
If the output was disabled (TxEN1, TxEN0 = “0”) and either
TxEN1 or TxEN0, or both are setto 1, the device will not start
transmission or reception of a frame until eleven consecutive
“recessive” bits have been received.
A “bus off” condition will also cause the output drivers Tx1
and Tx0 to be at TRI-STATE (independent of the status of
TxEN1 and TxEN0). The device will switch from “bus off” to
“error active” mode as described under the FMOD-bit description (see Can BusControl register). This will ensure that
the device is synchronized to the bus, before starting to
transmit or receive.
For information on bus synchronization and status of the
CAN related registers afterexternal reset refer to the RESET
section.
ON-CHIP VOLTAGE REFERENCE
The on-chip voltage reference is a ratiometric reference. For
electrical characteristics of the voltage reference refer to the
electrical specifications section.
ANALOG SWITCHES
Analog switches are used for selecting between Rx0 and
V
and between Rx1 and V
REF
(Continued)
.
REF
Basic CAN Concepts
The following paragraphs provide a generic overview of the
basic concepts of the Controller Area Network (CAN) as described in
lated issues of the National Semiconductor device will be
discussed as well.
This device will process standard frame format only. Extended frame formats will be acknowledged, however the
data will be discarded. For this reason the description of
frame formats in the following section will cover only the
standard frame format.
The following section provides some more detail on how the
device will handle received extended frames:
If the device’s remote identifier acceptance filter bit (RIAF) is
set to “1”, extended frame messages will be acknowledged.
However, the data will be discarded and the device will not
reply to a remote transmission request received in extended
frame format. If the device’s RIAF bit is set to “0”, the upper
7 received ID bits of an extended frame that match the device’s receive identifier (RID) acceptance filtler bits, are
stroed in the device’s RIDregister. However, the device does
not reply to an RTR and any data is discarded. The device
will only acknowledge the message.
MULTI-MASTER PRIORITY BASED BUS ACCESS
The CAN protocol is message based protocol that allows a
total of 2032 (= 2
format and 512 million (= 2
extended frame format.
MULTICAST FRAME TRANSFER BY
ACCEPTANCE FILTERING
Every CAN Frame is put on the common bus. Each module
receives every frame and filters out the frames which are not
required for the module’s task.
Chapter 4 of ISO/DIS11519-1.
11
−16) different messages in the standard
29
−16) different messages in the
Implementation re-
REMOTE DATA REQUEST
A CAN master module has the ability to set a specific bit
called the “remote transmission request bit” (RTR) in a
frame. This causes another module, either another master or
a slave, to transmit a data frame after the current frame has
been completed.
SYSTEM FLEXIBILITY
Additional modules can be added to an existing network
without a configuration change. These modules can either
perform completely new functions requiring new data or process existing data to perform a new function.
SYSTEM WIDE DATA CONSISTENCY
As the CAN network is message oriented, a message can be
used like a variable which is automatically updated by the
controlling processor. If any module cannot process information it can send an overload frame. The device is incapable
of initiating an overload frame, but will join a overload frame
initiated by another device as required by CAN specifications.
NON-DESTRUCTIVE CONTENTION-BASED
ARBITRATION
The CAN protocol allows several transmitting modules to
start a transmission at the same time as soon as they monitor the bus to be idle. During the start of transmission every
node monitors the bus line to detect whether its message is
overwritten by a message with a higher priority.As soon as a
transmitting module detects another module with a higher
priority accessing the bus, it stops transmitting its own frame
and switches to receive mode. For illustration see
AUTOMATIC RETRANSMISSION OF FRAMES
If a data or remote frame is overwritten by either a higherprioritized data frame, remote frame or an error frame, the
transmitting module will automatically retransmit it. This device will handle the automatic retransmission of up to two
data bytes automatically. Messages with more than 2 data
bytes require the user’s software to update the transmit registers.
ERROR DETECTION AND ERROR SIGNALING
All messages on the bus are checked by each CAN node
and acknowledge if they are correct. If any node detects an
error it starts the transmission of an error frame.
Switching Off Defective Nodes
There are two error counters, one for transmitted data and
one for received data, which are incremented, depending on
the error type, as soon as an error occurs. If either counter
goes beyond a specific value thenode goes to an error state.
A valid frame causes the error counters to decrease.
The device can be in one of three states with respect to error
handling:
Error active
•
An error active unit can participate in bus communication
and sends an active (“dominant”) error flag.
Error passive
•
An error passive unit can participate in bus communication. However, if the unit detects an error it is not allowed
to send an active errorflag. The unit sends only a passive
(“recessive”) error flag.
Figure 18
.
www.national.com 28
Page 29
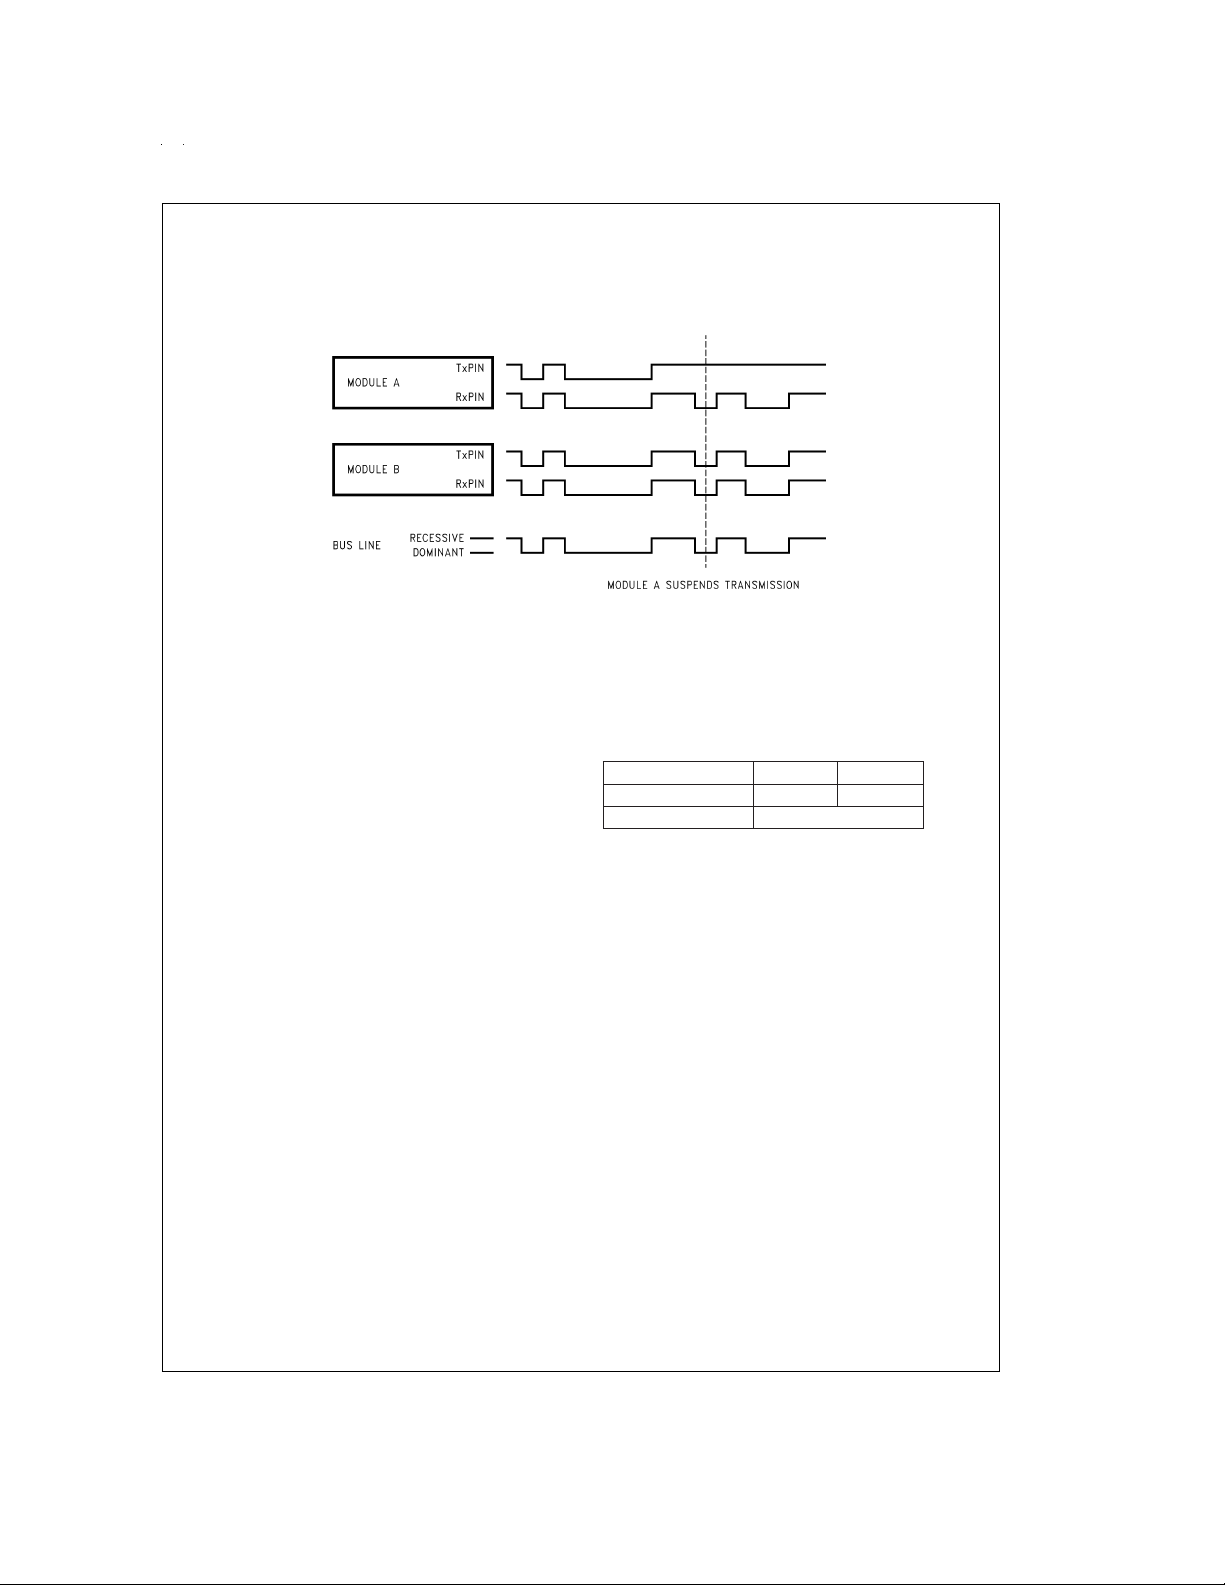
Basic CAN Concepts (Continued)
Bus off
•
A unit that is “bus off” has the output drivers disabled, i.e., it
does not participate in any bus activity.
FIGURE 18. CAN Message Arbitration
Frame Formats
INTRODUCTION
There are basically two different types of frames used in the
CAN protocol.
The data transmission frames are:: data/remote frame
The control frames are:: error/overload frame
Note: This device cannot send an overload frame as a result of not being
able to process all information. However, the device is able to recognize an overload condition and join overload frames initiated by other
devices.
If no message is being transmitted, i.e., the bus is idle, the
bus is kept at the “recessive” level.
give an overview of the various CAN frame formats.
DATA AND REMOTE FRAME
Data frames consist of seven bit fields and remote frames
consist of six different bit fields:
1. Start of Frame (SOF)
2. Arbitration field
3. Control field (IDE bit, R0 bit, and DLC field)
4. Data field (not in remote frame)
5. CRC field
6. ACK field
7. End of Frame (EOF)
A remote frame has no data field and is used for requesting
data from other (remote) CAN nodes.
format of a CAN data frame.
FRAME CODING
Remote and Data Frames are NRZ codes with bit-stuffing in
every bit field which holds computable information for the interface, i.e., Start of Frame arbitration field, control field, data
field (if present) and CRC field.
Error and overload frames are NRZ coded without bit stuffing.
Figure 19
Figure 21
and
shows the
Figure 20
(See ERROR MANAGEMENT AND DETECTION for more
detailed information.)
DS012837-20
BIT STUFFING
After five consecutive bits of the same value, a stuff bit of the
inverted value is inserted by the transmitter and deleted by
the receiver.
Destuffed Bit Stream 100000x 011111x
Stuffed Bit Stream 1000001x 0111110x
Note: x = {0,1}
START OF FRAME (SOF)
The Start of Frame indicates the beginning of data and remote frames. It consists of a single “dominant” bit. A node is
only allowed to start transmission when the bus is idle. All
nodes have to synchronize to the leading edge (first edge after the bus was idle) caused by SOF of the node which starts
transmission first.
ARBITRATION FIELD
The arbitration field is composed of the identifier field and the
RTR (Remote Transmission Request) bit. The value of the
RTR bit is “dominant” in a data frame and “recessive” in a remote frame.
CONTROL FIELD
The control field consists of six bits. It starts with two bits reserved for future expansion followed by the four-bit Data
Length Code. Receivers must accept all possible combinations of the two reserved bits. Until the function of these reserved bits is defined, the transmitter only sends “0” (dominant) bits. The first reserved bit (IDE) is actually defined to
indicate an extended frame with 29 Identifier bits if set to “1”.
CAN chips must tolerate extended frames, even if they can
only understand standard frames, to prevent the destruction
of an extended frames on an existing network.
The Data Length Code indicates the number of bytes in the
data field. This Data Length Code consists of four bits. The
data field can be of length zero. The permissible number of
data bytes for a data frame ranges from 0 to 8.
www.national.com29
Page 30
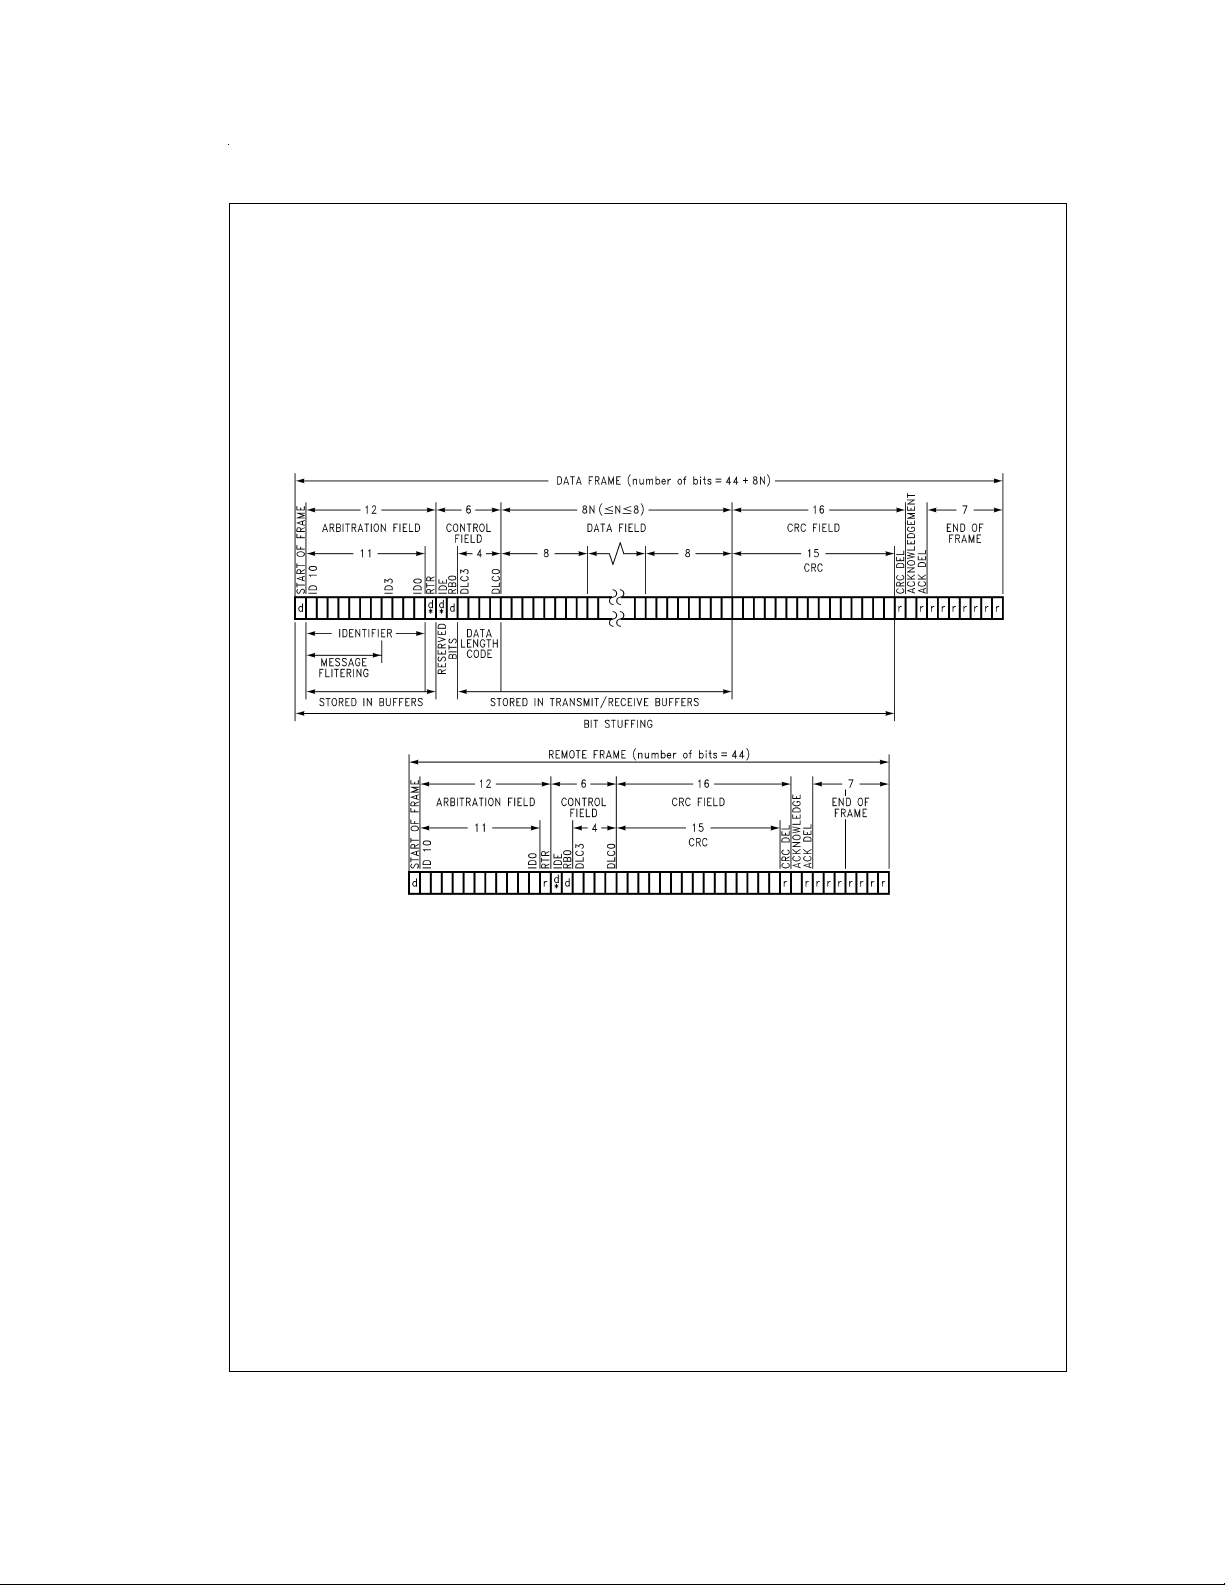
Frame Formats (Continued)
DATA FIELD
The Data field consists of the data to be transferred within a
data frame. It can contain 0 to 8 bytes and each byte contains 8 bits. A remote frame has no data field.
CRC FIELD
The CRC field consists of the CRC sequence followed by the
CRC delimiter. The CRC sequence is derived by the transmitter from the modulo 2 division of the preceding bit fields,
starting with the SOF up to the end of the data field, excluding stuff-bits, by the generator polynomial:
15
χ
+ χ14+ χ10+ χ8+ χ7+ χ4+ χ3+1
The remainder of this divisionis the CRC sequence transmitted over the bus. On the receiver side the module divides all
bit fields up to the CRC delimiter, excluding stuff-bits, and
checks if the result is zero. This will then be interpreted as a
valid CRC. After the CRC sequence a single “recessive” bit
is transmitted as the CRC delimiter.
DS012837-21
A remote frame is identical to a data frame, except that the RTR bit is “recessive”, and there is no data field.
IDE = Identifier Extension Bit
The IDE bit in the standard format is transmitted “dominant”, whereas in the extended format the IDE bit is “recessive” and the id is expanded to 29 bits.
r = recessive
d = dominant
DS012837-22
FIGURE 19. CAN Data Transmission Frames
www.national.com 30
Page 31

Frame Formats (Continued)
An error frame can start anywhere in the middle of a frame.
INT = Intermission
Suspend Transmission is only for error passive nodes.
An overload frame can only start at the end of a frame.
DS012837-23
DS012837-24
DS012837-25
FIGURE 20. CAN Control Frames
DS012837-26
FIGURE 21. CAN Frame Format
ACK FIELD
The ACK field is two bits long and contains theACK slot and
theACK delimiter.The ACK slot is filled with a “recessive” bit
by the transmitter. This bit is overwritten with a “dominant” bit
by every receiver that has received a correct CRC sequence. The second bit of the ACK field is a “recessive” bit
called the acknowledge delimiter.As a consequence the acknowledge flag of a valid frame is surrounded by two “recessive” bits, the CRC-delimiter and the ACK delimiter.
EOF FIELD
The End of Frame Field closes a data and a remote frame. It
consists of seven “recessive” bits.
INTERFRAME SPACE
Data and remote frames are separate from every preceding
frame (data, remote, error and overload frames) by the interframe space see
Figure 22
and
Figure 23
for details. Error
and overload frames are not preceded by an interframe
space. They can be transmitted as soon as the condition occurs. The interframe space consists of a minimum of three
bit fields depending on the error state of the node.
These bit fields are coded as follows:
The intermission has the fixed form of three “recessive” bits.
While this bit field is active, no node is allowed to start a
transmission of a data or a remote frame. The only action to
be taken is signaling an overload condition. This means that
an error in this bit field would be interpreted as an overload
condition. Suspend transmission has to be inserted by errorpassive nodes that were transmitter for the last message.
This bit field has the form of eight “recessive” bits. However,
it may be overwritten by a “dominant” start-bit from another
non error passive node which starts transmission. The bus
idle field consists of “recessive” bits. Its length is not specified and depends on the bus load.
www.national.com31
Page 32
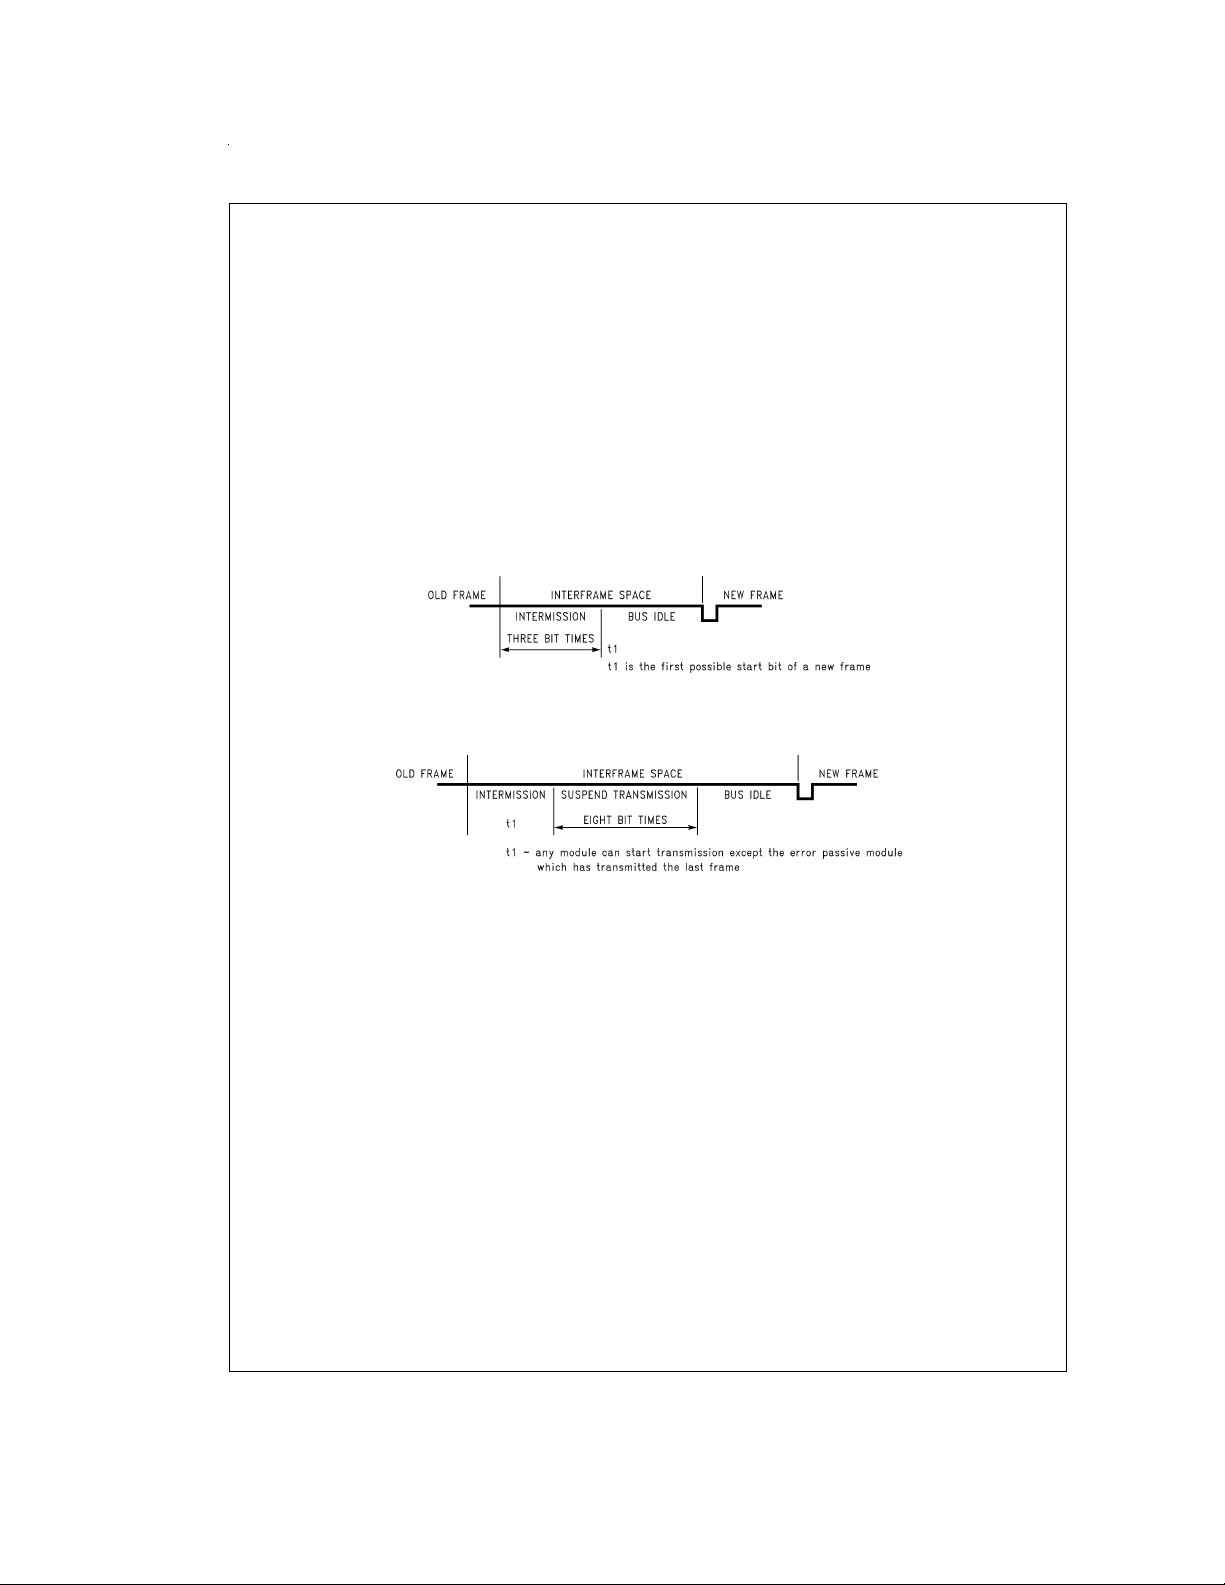
Frame Formats (Continued)
ERROR FRAME
The Error Frame consists of two bit fields: the error flag and
the error delimiter. The error field is built up from the various
error flags of the different nodes. Therefore, its length may
vary from a minimum of six bits up to a maximum of twelve
bits depending on when a module detects the error. Whenever a bit error,stuff error,form error,or acknowledgment error is detected by anode, this node starts transmissionof the
error flag at the next bit. If a CRC error is detected, transmission of the error flag starts at the bit following the acknowledge delimiter, unless an error flag for a previous error condition has already been started.
fault at one module (module 2) leads to a 12-bit error frame
on the bus.
The bus level may either be “dominant” for an error-active
node or “recessive” for an error-passive node. An error active node detecting an error, starts transmitting an active er-
Figure 24
shows how a local
FIGURE 22. Interframe Space for Nodes Which Are Not
Error Passive or Have Been Receiver for the Last Frame
ror flag consisting of six “dominant” bits. This causes the destruction of the actual frame on the bus. The other nodes
detect the error flag as either a violation of the rule of bitstuffing or the value of a fixed bit field is destroyed.As a consequence all other nodes start transmission of their own error flag. This means, that the error sequence which can be
monitored on the bus as a maximum length of twelve bits. If
an error passive node detects an error it transmits six “recessive” bits on the bus. This sequence does not destroy a message sent by another node and is not detected by other
nodes. However, if the node detecting an error was the
transmitter of the frame the other modules will get an error
condition by a violation of the fixed bit or stuff rule.
Figure 25
shows how an error passive transmitter transmits a passive
error frame and when it is detected by the receivers.
After any module has transmitted its active or passive error
flag it waits for the error delimiter which consists of eight “recessive” bits before continuing.
DS012837-27
FIGURE 23. Interframe Space for Nodes Which Are Error Passive
and Have Been Transmitter for the Last Frame
www.national.com 32
DS012837-28
Page 33
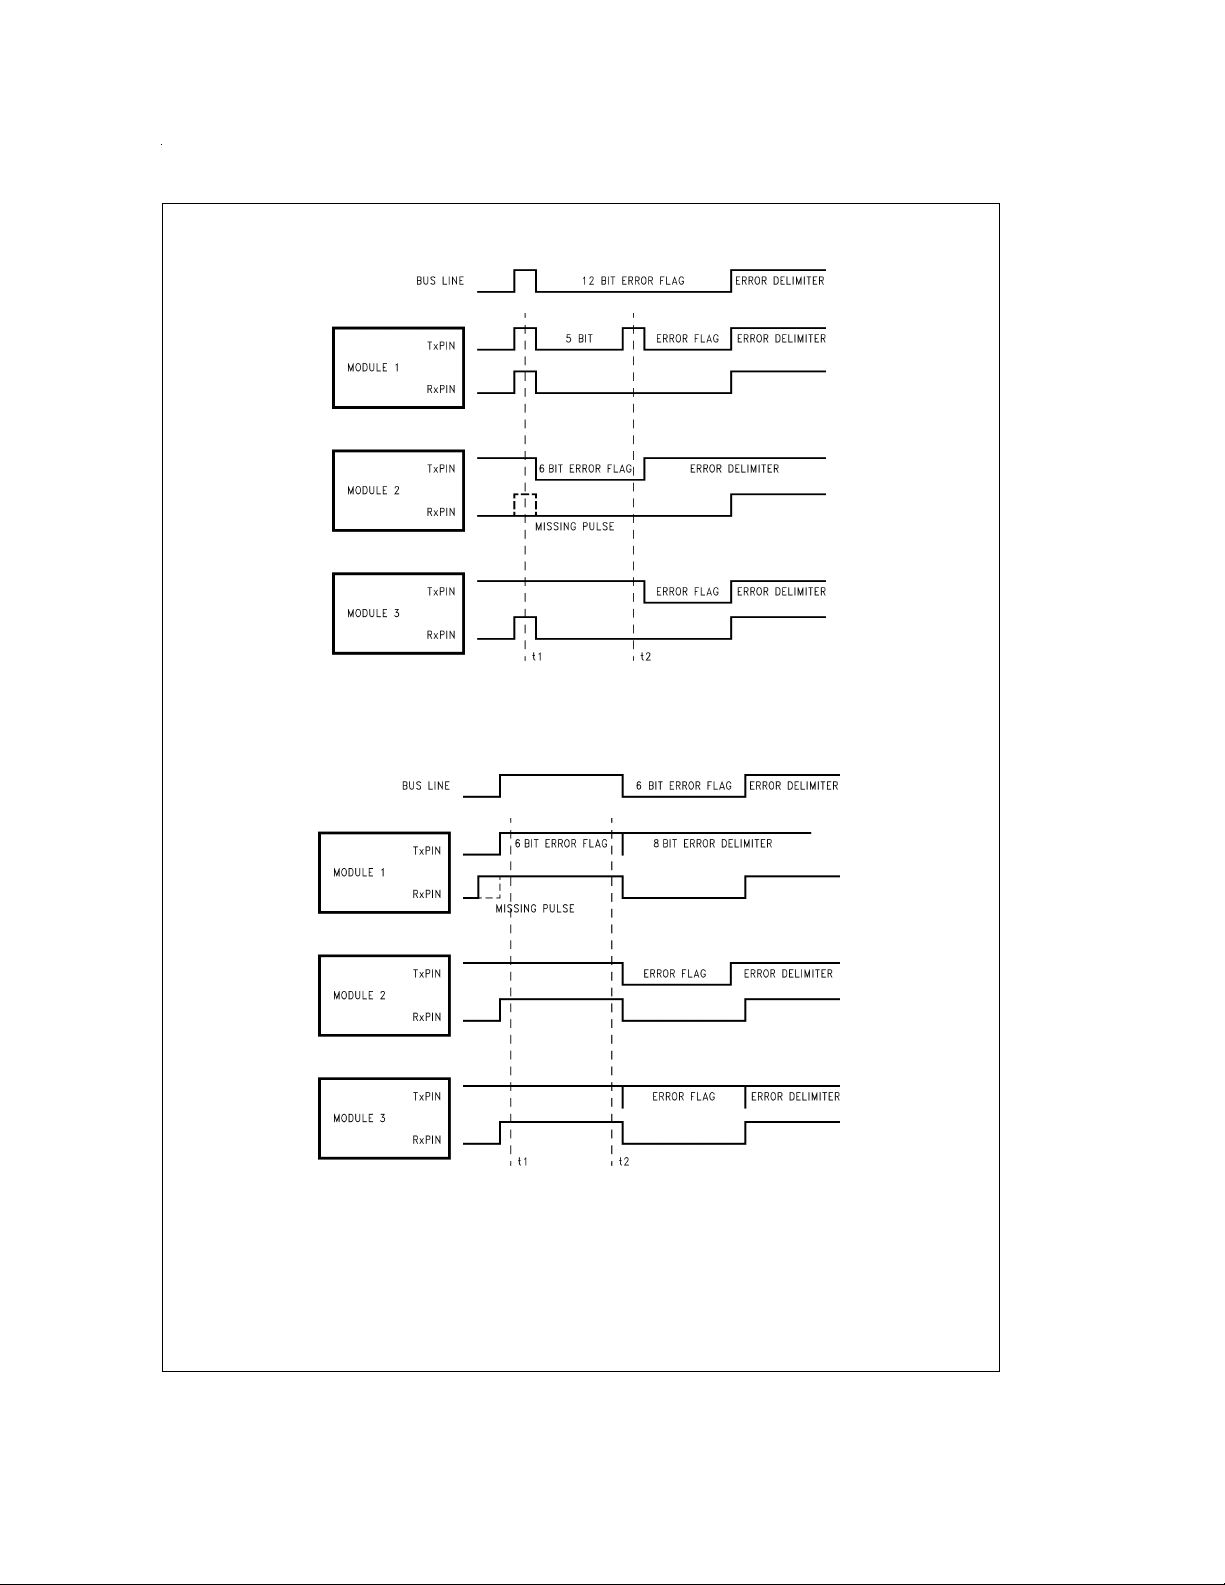
Frame Formats (Continued)
module 1 = error active transmitter detects bit error at t2
module 2 = error active receiver with a local fault at t1
module 3 = error active receiver detects stuff error at t2
FIGURE 24. Error Frame— Error Active Transmitter
module 1 = error active receiver with a local fault at t1
module 2 = error passive transmitter detects bit error at t2
module 3 = error passive receiver detects stuff error at t2
FIGURE 25. Error Frame— Error Passive Transmitter
DS012837-29
DS012837-30
OVERLOAD FRAME
Like an error frame, an overload frame consists of two bit
fields: the overload flag and the overload delimiter. The bit
fields have the same length as the error frame field: six bits
for the overload flag and eight bits for the delimiter.The over-
load frame can only be sent after the end of frame (EOF)
field and in they way destroys the fixed form of the intermission field.
www.national.com33
Page 34
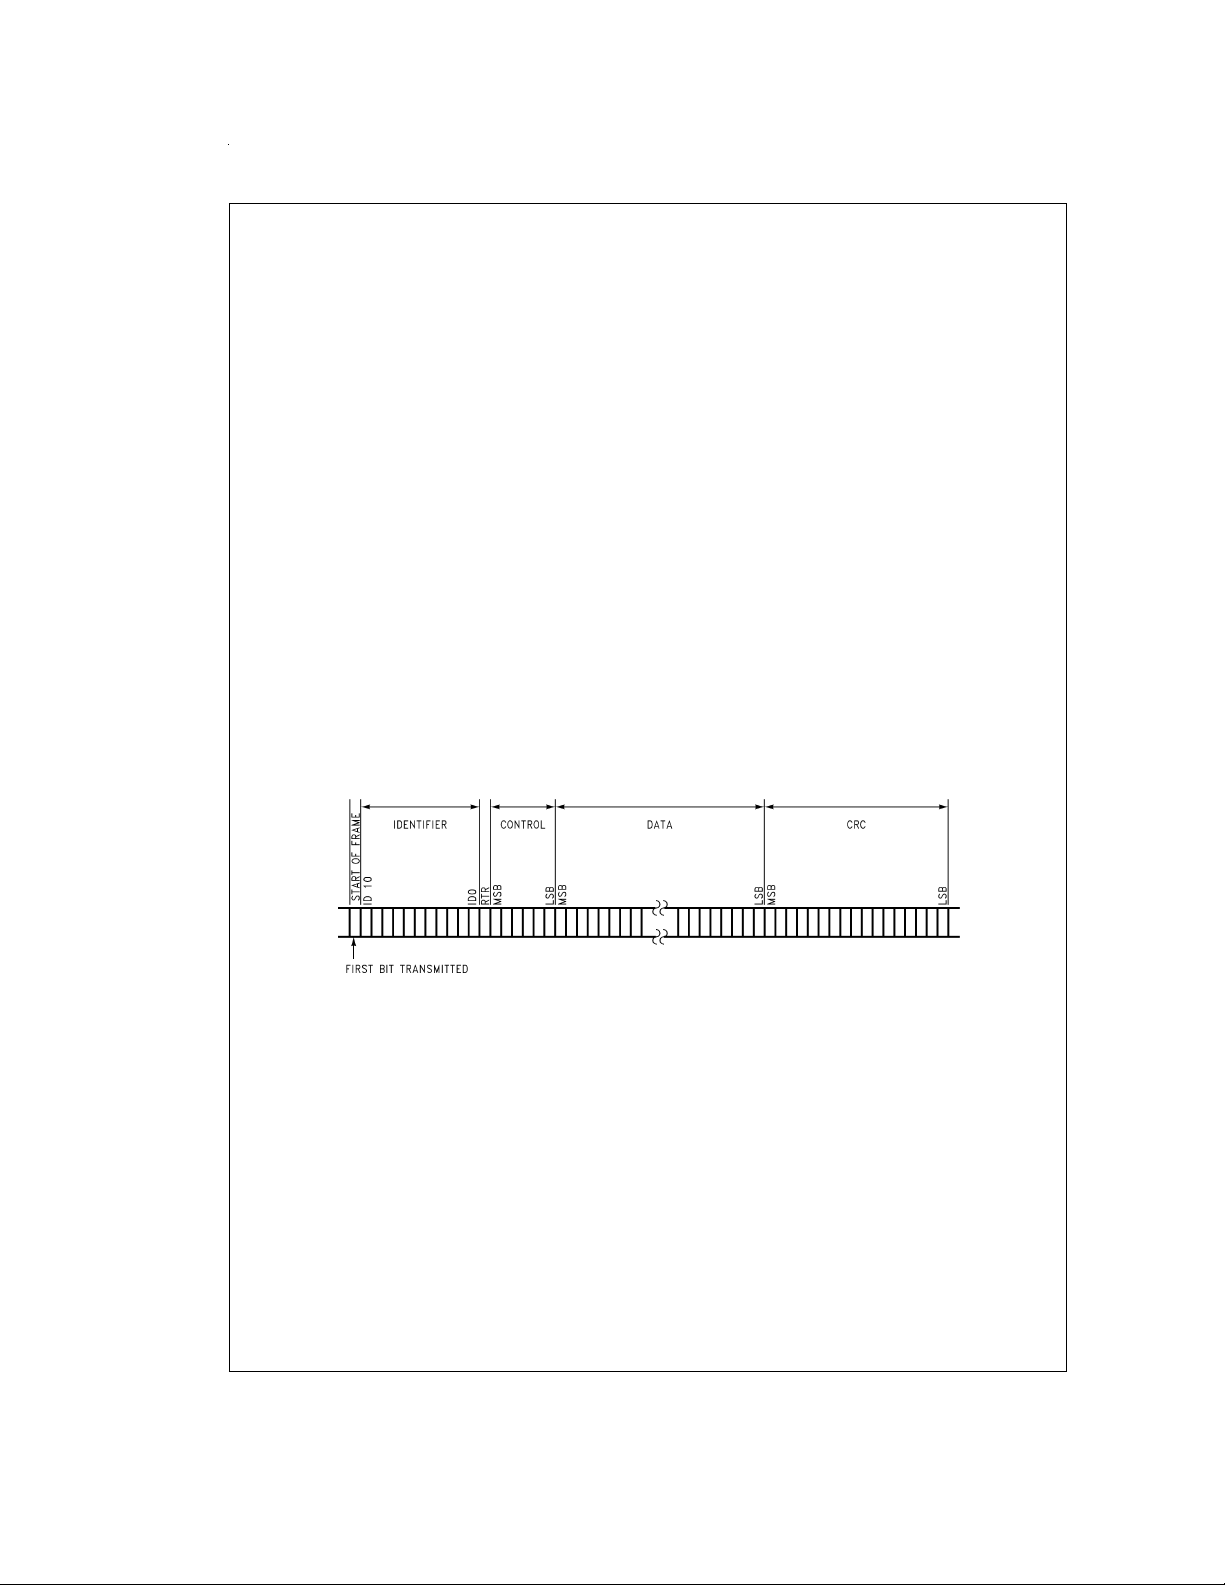
Frame Formats (Continued)
ORDER OF BIT TRANSMISSION
A frame is transmitted starting with the Start of Frame, sequentially followed by the remaining bit fields. In every bit
field the MSB is transmitted first.
FRAME VALIDATION
Frames have a different validation point for transmitters and
receivers.A frame is valid for the transmitter of a message, if
there is no error until the end of the last bit of the End of
Frame field. A frame is valid for a receiver, if there is no error
until and including the end of the penultimate bit of the End
of Frame.
FRAME ARBITRATION AND PRIORITY
Except for an error passive node which transmitted the last
frame, all nodes are allowed to start transmission of a frame
after the intermission, which can lead to two or more nodes
starting transmission at the same time. To prevent a node
from destroying another node’s frame, it monitors the bus
during transmission of the identifier field and the RTR-bit.As
soon as it detects a “dominant” bit while transmitting a “recessive” bit it releases the bus, immediately stops transmission and starts receiving the frame. This causes no data or
remote frame to be destroyed by another. Therefore the
highest priority message with the identifier 0x000 out of
0x7EF (including the remote data request (RTR) bit) always
gets the bus. This is only valid for standard CAN frame format. Note that while the CAN specification allows valid standard identifiers only in the range 0x000 to 0x7EF, the device
will allow identifiers to 0x7FF.
There are three more items that should be taken into consideration to avoid unrecoverable collisions on the bus:
Within one system each message must be assigned a
•
unique identifier.This is to prevent bit errors, as one module may transmit a “dominant” data bit while the other is
transmitting a “recessive” data bit. This could happen if
two or more modules start transmission of a frame at the
same time and all win arbitration.
Data frames with a given identifier and a non-zero data
•
length code may be initiated by one node only. Otherwise, in worst case, two nodes would count upto the busoff state, due to bit errors, if they always start transmitting
the same ID with different data.
Every remote frame should have a system-wide data
•
length code (DLC). Otherwise two modules starting
transmission of a remote frame at the same time will
overwrite each other’s DLC which result in bit errors.
ACCEPTANCE FILTERING
Every node may perform acceptance filtering on the identifier of a data or a remote frame to filter out the messages
which are not required by the node. In theyway only the data
of frames which match the acceptance filter is stored in the
corresponding data buffers. However, every node which is
not in the bus-off state and has received a correct CRCsequence acknowledges each frame.
ERROR MANAGEMENT AND DETECTION
There are multiple mechanisms in the CAN protocol, to detect errors and to inhibit erroneous modules from disabling
all bus activities.
FIGURE 26. Order of Bit Transmission within a CAN Frame
The following errors can be detected:
Bit Error
•
A CAN device that is sending also monitors the bus. If the
monitored bit value is different from the bit value that is sent,
a bit error is detected. The reception of a “dominant” bit instead of a “recessive” bit during the transmission of a passive error flag, during the stuffed bit stream of the arbitration
field or during the acknowledge slot, is not interpreted as a
bit error.
Stuff error
•
A stuff error is detected, if the bit level after 6 consecutive bit
times has not changed in a message field that has to be
coded according to the bit stuffing method.
www.national.com 34
DS012837-31
Form Error
•
Aform error is detected, if a fixed frame bit (e.g., CRC delimiter,ACK delimiter) does not have the specified value. For a
receiver a “dominant” bit during the last bit of End of Frame
does NOT constitute a form error.
Bit CRC Error
•
ACRC error is detected if the remainder of the CRC calculation of a received CRC polynomial is non-zero.
Acknowledgment Error
•
An acknowledgment error is detected whenever a transmitting node does not get an acknowledgment from any other
node (i.e., when the transmitter does not receive a “dominant” bit during the ACK frame).
The device can be in one of three states with respect to error
handling:
Error active
•
Page 35
Frame Formats (Continued)
An error active unit can participate in bus communication
and sends an active (“dominant”) error flag.
Error passive
•
An error passive unit can participate in bus communication.
However, if the unit detects an error it is not allowed to send
an active error flag. The unit sends only a passive (“recessive”) error flag. A device is error passive when the transmit
error counter is greater than 127 or when the receive error
counter is greater than 127.A device becoming errorpassive
sends an active error flag. An error passive device becomes
error active again when both transmit and receive error
counter are less than 128.
Bus off
•
A unit that is “bus off” has the output drivers disabled, i.e., it
does not participate in any bus activity. A device is bus off
when the transmit error counter is greater than 255. Abus off
device will become error active again in one of two ways depending on which mode is selected by the user through the
Fault Confinement Mode select bit (FMOD) in the CAN Bus
Control Register (CBUS). Setting the FMOD bit to “0” (default after power on reset) will select the Standard Fault Confinement mode. In this mode the device goes from “bus off”
to “error active” after monitoring 128*11 recessive bits (including bus idle) on the bus. This mode has been implemented for compatibility reasons with existing solutions. Setting the FMOD bit to “1” will select the Enhanced Fault
Confinement mode. In this mode the device goes from “bus
off” to “error active” after monitoring 128 “good” messages,
as indicated by the reception of 11 consecutive “recessive”
bits including the End of Frame. The enhanced mode offers
the advantage that a “bus off” device (i.e., adevice with a serious fault) is not allowed to destroy any messages on the
bus until other devices can transmit at least 128 messages.
This is not guaranteed in the standard mode, where a defective device could seriously impact buscommunication. When
the device goes from “bus off” to “error active”, both error
counters will have the value “0”.
In each CAN module there are two error counters to perform
a sophisticated error management. The receive error
counter (REC) is 7 bits wide and switches the device to the
error passive state if it overflows. The transmit error counter
(TEC) is 8 bits wide. If it is greater than 127, the device is
switched to the error passive state. As soon as the TEC
overflows, the device is switched bus-off, i.e., it does not participate in any bus activity.
The counters are modified by the device’s hardware according to the following rules:
TABLE 8. Receive Error Counter Handling
Condition Receive Error
Counter
A receiver detects a Bit Error
during sending an active error flag.
A receiver detects a “dominant” bit
as the first bit after sending an
error flag.
Increment by 8
Increment by 8
Condition Receive Error
Counter
After detecting the 14th consecutive
“dominant” bit following an active
error flag or overload flag or after
detecting the 8th consecutive
“dominant” bit following a passive
error flag. After each sequence of
additional 8 consecutive “dominant”
bits.
Any other error condition (stuff,
frame, CRC, ACK).
A valid reception or transmission. Decrement by 1 if
TABLE 9. Transmit Error Counter Handling
Condition Transmit Error
A transmitter detects a Bit Error
during sending an active error
flag.
After detecting the 14th
consecutive “dominant” bit
following an active error flag or
overload flag or after detecting
the 8th consecutive “dominant”
bit following a passive error
flag. After each sequence of
additional 8 consecutive
“dominant” bits.
Any other error condition (stuff,
frame, CRC, ACK).
A valid reception or
transmission.
Special error handling for the TEC counter is performed in
the following situations:
A stuff error occurs during arbitration, when a transmitted
•
“recessive” stuff bit is received as a “dorminant” bit. This
does not lead to an incrementation of the TEC.
An ACK-error occurs in an error passive device and no
•
“dominant” bits are detected while sending the passive
error flag. This does not lead to an incrementation of the
TEC.
If only one device is on the bus and this device transmits
•
a message, it will get no acknowledgment. This will be
detected as an error and message will be repeated.
When the device goes “error passive” and detects an acknowledge error, the TEC counter is not incremented.
Therefore the device will not go from “error passive” to
the “bus off” state due to such a condition.
Figure 27
cording to the error counters.
shows the connection of different bus states ac-
Increment by 8
Increment by 1
Counter is not 0
Counter
Increment by 8
Increment by 8
Increment by 8
Decrement by
1 if Counter is not 0
www.national.com35
Page 36
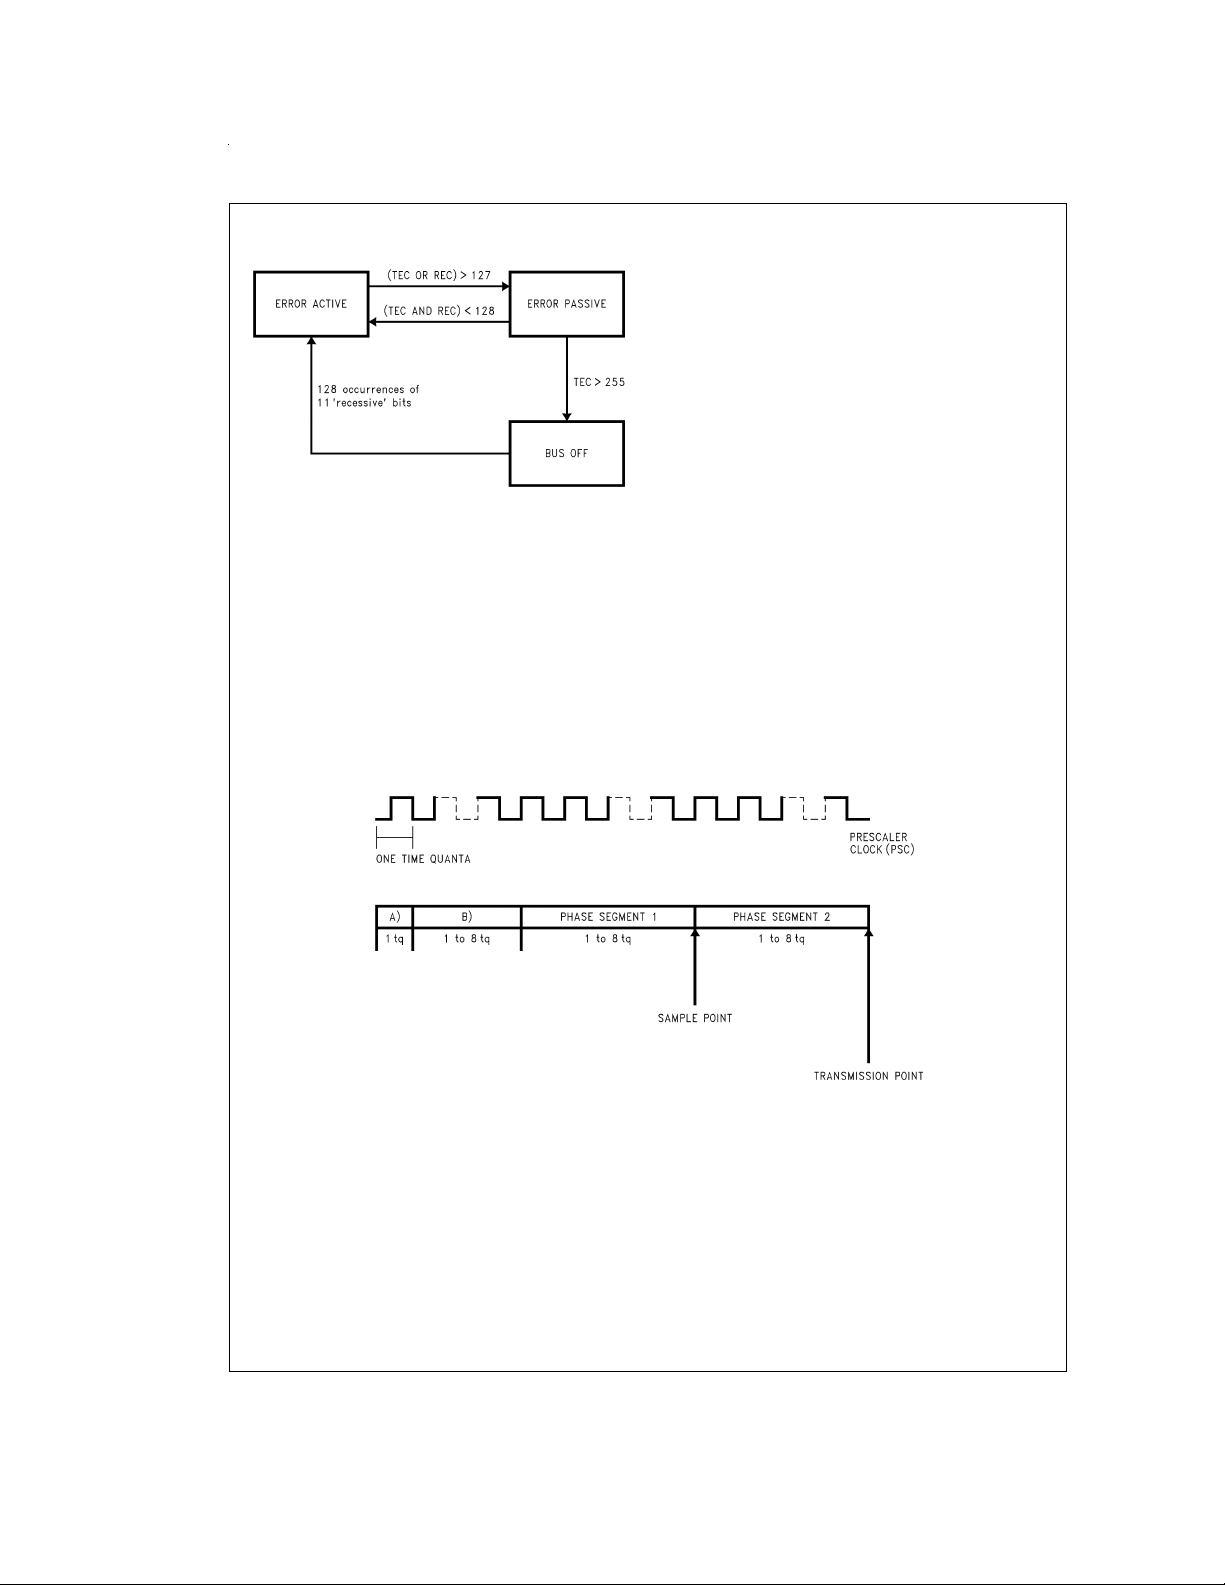
Frame Formats (Continued)
DS012837-32
FIGURE 27. CAN Bus States
SYNCHRONIZATION
Every receiver starts with a “hard synchronization” on the
falling edge of the SOF bit. One bit time consists of four bit
segments: Synchronization segment, propagation segment,
phase segment 1 and phase segment 2.
A falling edge of the data signal should be in the synchronization segment. This segment has the fixed length of one
time quanta. To compensate for the various delays within a
network, the propagation segment is used. Its length is programmable from 1 to 8 time quanta. Phase segment 1 and
phase segment 2 are used to resynchronize during an active
frame. The length of these segments is from 1 to 8 time
quanta long.
Two types of synchronization are supported:
Hard synchronization is done with the falling edge on the
bus while the bus is idle, which is then interpreted as the
SOF. It restarts the internal logic.
Soft synchronization is used to lengthen or shorten the bit
time while a data or remote frame is received. Whenever a
falling edge is detected in the propagation segment or in
phase segment 1, the segment is lengthened by a specific
value, the resynchronization jump width (see
If a falling edge liesin the phase segment 2 (as shownin
ure 29
) it is shortened by the resynchronization jump width.
Figure 29
).
Fig-
Only one resynchronization is allowed during one bit time.
The sample point lies between the two phase segments and
is the point where the received data is supposed to be valid.
The transmission point lies at the end of phase segment 2 to
start a new bit time with the synchronization segment.
1. The resynchronization jump width (RJW) is automatically determined from the programmed value of PS. If a
soft resynchronization is done during phase segment 1
or the propagation segment, then RJW will either be
equal to 4 internal CAN clocks (CKI/(1
+ divider)
)orthe
programmed value of PS, whichever is less. PS2 will
never be shorter than 1 internal CAN clock.
2. (PS1 —BTL settings any PSC setting) The PS1 of the
BTL should always be programmed to values greater
than 1. To allow device resynchronization for positive
and negative phase errors on the bus. (if PS1 is programmed to one, a bit time could only be lengthened
and never shortened which basically disables half of the
synchronization).
A) Synchronization segment
B) Propagation segment
FIGURE 28. Bit Timing
www.national.com 36
DS012837-33
Page 37
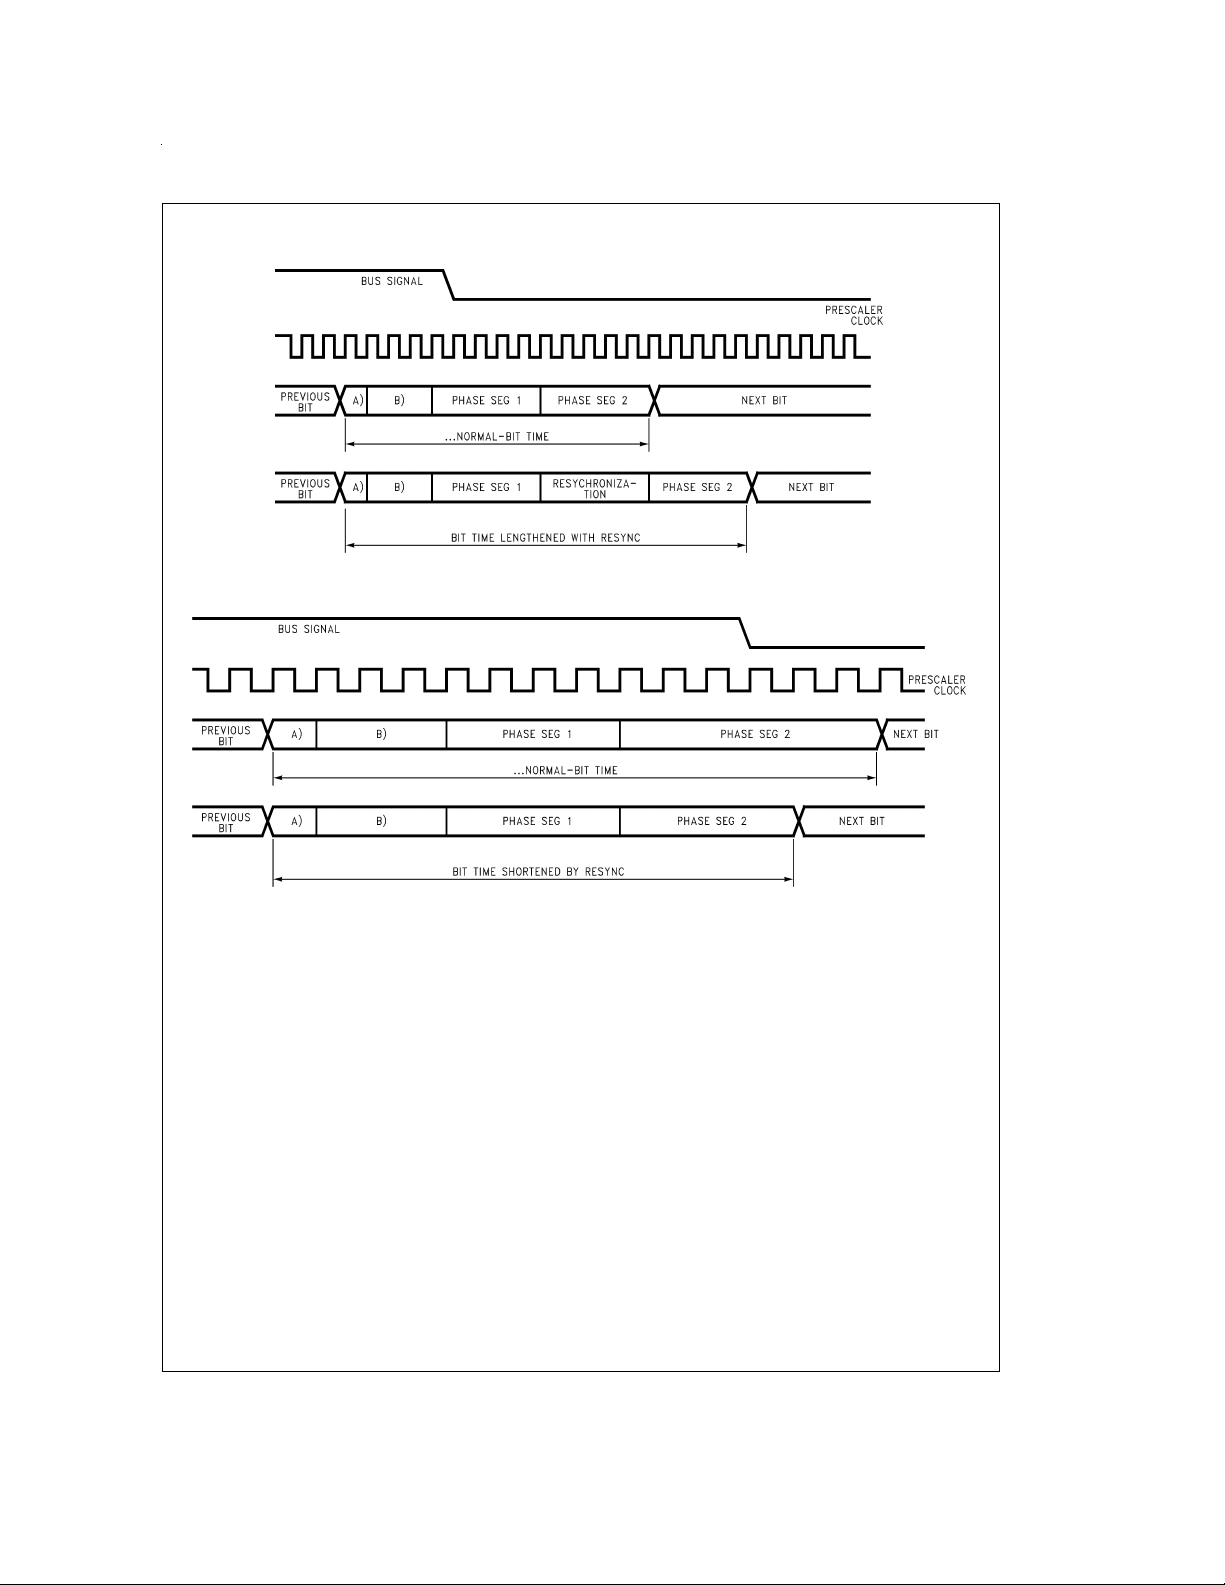
Frame Formats (Continued)
DS012837-34
FIGURE 29. Resynchronization 1
FIGURE 30. Resynchronization 2
Interrupts
INTRODUCTION
Each device supports fourteen vectored interrupts. Interrupt
sources include Timer 0, Timer 1, Timer 2, Timer 3, Port L
Wakeup, Software Trap, MICROWIRE/PLUS, and External
Input.
All interrupts force a branch to location 00FF Hex in program
memory. The VIS instruction may be used to vector to the
appropriate service routine from location 00FF Hex.
DS012837-35
The Software trap has the highest priority while the default
VIS has the lowest priority.
Each of the 14 maskable inputs has a fixed arbitration ranking and vector.
Figure 31
shows the Interrupt Block Diagram.
www.national.com37
Page 38
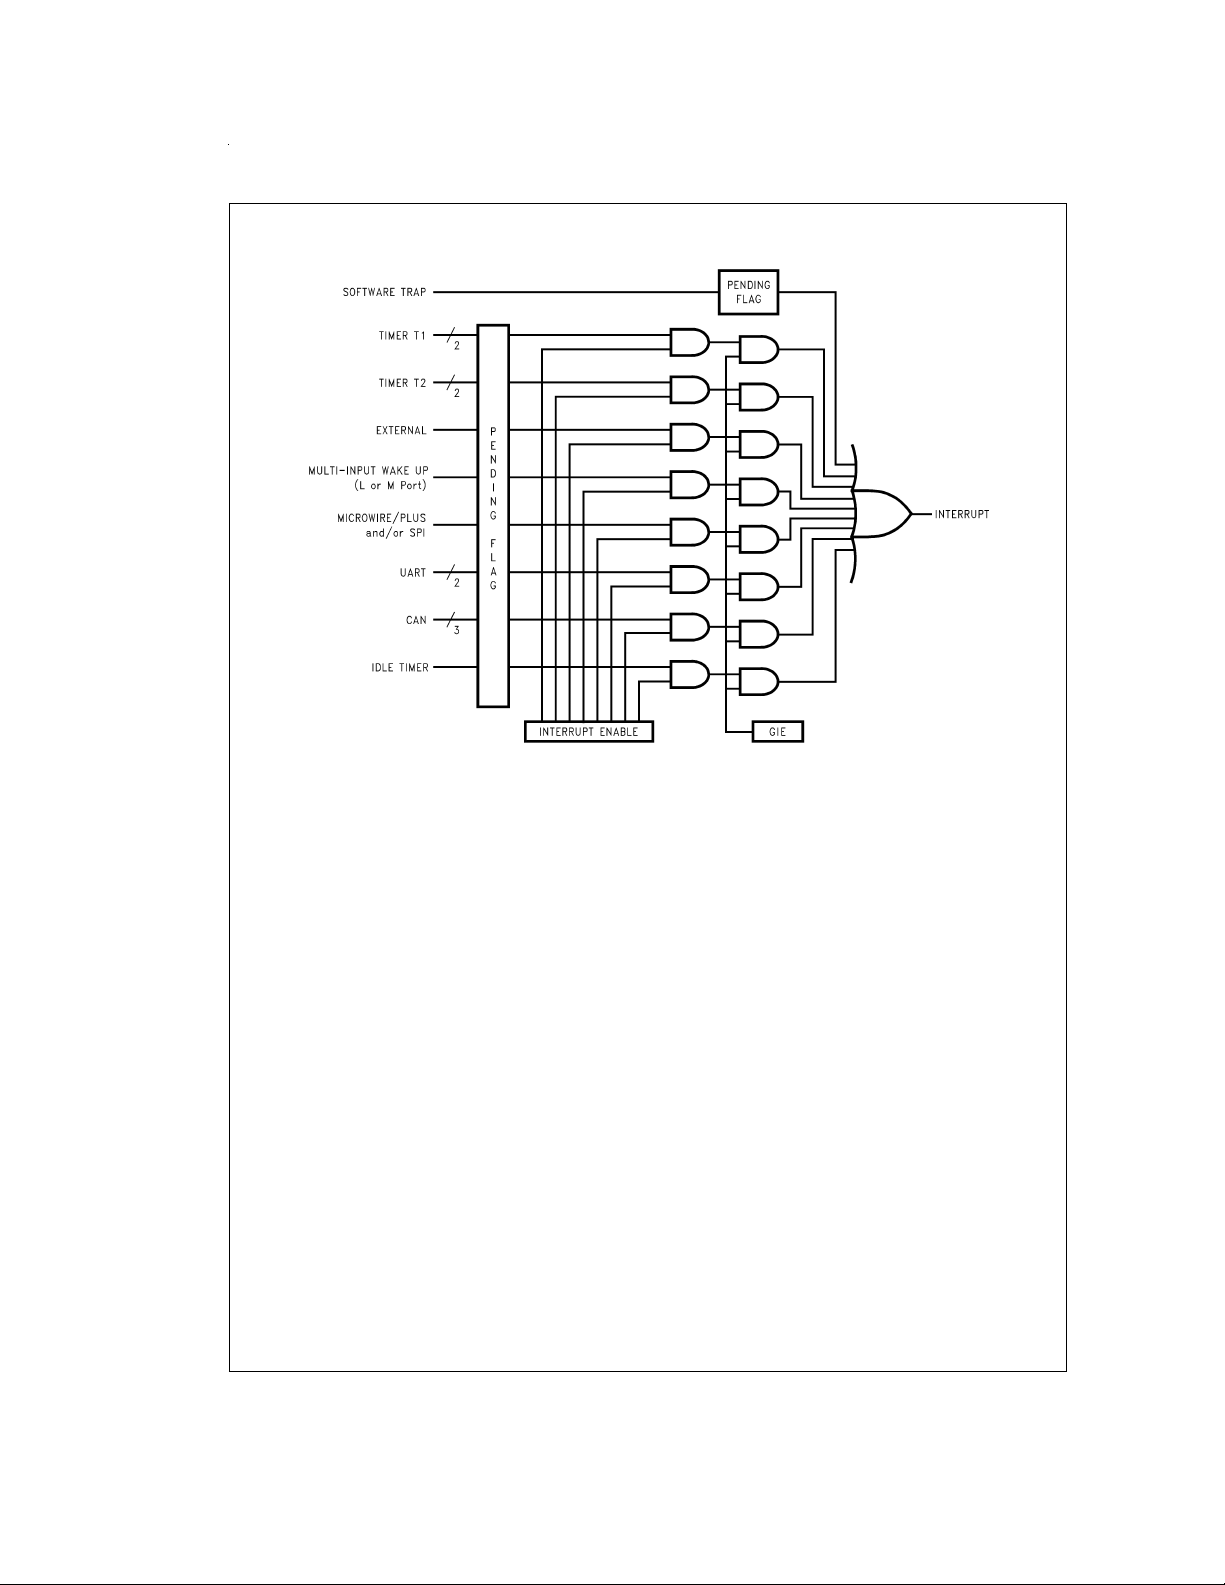
Interrupts (Continued)
DS012837-15
FIGURE 31. Interrupt Block Diagram
www.national.com 38
Page 39

Interrupts (Continued)
MASKABLE INTERRUPTS
All interrupts other than the Software Trap are maskable.
Each maskable interrupt has an associated enable bit and
pending flag bit. The pending bit is set to 1 when the interrupt
condition occurs. The state of the interrupt enable bit, combined with the GIE bit determines whether an active pending
flag actually triggers an interrupt. All of the maskable interrupt pending and enable bits are contained in mapped control registers, and thus can be controlled by the software.
Amaskable interrupt condition triggers an interrupt under the
following conditions:
1. The enable bit associated with that interrupt is set.
2. The GIE bit is set.
3. The device is not processing a non-maskable interrupt.
(If a non-maskable interrupt is being serviced, a
maskable interrupt must wait until that service routine is
completed.)
An interrupt is triggered only when all of these conditions are
met at the beginning of an instruction. If different maskable
interrupts meet these conditions simultaneously, the highest
priority interrupt will be serviced first, and the other pending
interrupts must wait.
Upon Reset, all pending bits, individual enable bits, and the
GIE bit are reset to zero. Thus, a maskable interrupt condition cannot trigger an interrupt until the program enables it by
setting both the GIE bit and the individual enable bit. When
enabling an interrupt, the user should consider whether or
not a previously activated (set) pending bit should be acknowledged. If, at the time an interrupt is enabled, any previous occurrences of the interrupt should be ignored, the associated pending bit must be reset to zero prior to enabling
the interrupt. Otherwise, the interrupt may be simply enabled; if the pending bit is already set, it will immediately trigger an interrupt. A maskable interrupt is active if its associated enable and pending bits are set.
An interrupt is an asychronous event which may occur before, during, or after an instruction cycle. Any interrupt which
occurs during the execution of an instruction is not acknowledged until the start ofthe next normally executed instruction
is to be skipped, the skip is performed before the pending interrupt is acknowledged.
At the start of interrupt acknowledgment, the following actions occur:
1. The GIE bitis automatically reset to zero, preventing any
subsequent maskable interrupt from interrupting the current service routine. This feature prevents one maskable
interrupt from interrupting another one being serviced.
2. The address of the instruction about to be executed is
pushed onto the stack.
3. The program counter (PC) is loaded with 00FF Hex,
causing a jump to that program memory location.
The device requires seven instruction cycles to perform the
actions listed above.
If the user wishes to allow nested interrupts, the interrupts
service routine may set the GIE bit to 1 by writing to the PSW
register,and thus allow other maskable interrupts to interrupt
the current service routine. If nested interrupts are allowed,
caution must be exercised. The user must write the program
in such a way as to prevent stack overflow, loss of saved
context information, and other unwanted conditions.
The interrupt service routine stored at location 00FF Hex
should use the VIS instruction to determine the cause of the
interrupt, and jump to the interrupt handling routine corresponding to the highest priority enabled and active interrupt.
Alternately, the user may choose to poll all interrupt pending
and enable bits to determine the source(s) of the interrupt. If
more than one interrupt is active, the user’s program must
decide which interrupt to service.
Within a specific interrupt service routine, the associated
pending bit should be cleared. This is typically done as early
as possible in the service routine in order to avoid missing
the next occurrence of the same type of interrupt event.
Thus, if the same event occursa second time, even while the
first occurrence is still being serviced, the second occurrence will be serviced immediately upon return from the current interrupt routine.
An interrupt service routine typically ends with an RETI instruction. This instruction sets the GIE bit back to 1, pops the
address stored on the stack, and restores that address to the
program counter. Program execution then proceeds with the
next instruction that would have been executed had there
been no interrupt. If there are any valid interrupts pending,
the highest-priority interrupt is serviced immediately upon return from the previous interrupt.
VIS INSTRUCTION
The general interrupt service routine, which starts at address
00FF Hex, must be capable of handling all types of interrupts. The VIS instruction, together with an interrupt vector
table, directs the device tothe specific interrupt handling routine based on the cause of the interrupt.
VIS is a single-byte instruction, typically used at the very beginning of the general interrupt service routine at address
00FF Hex, or shortly after that point, just after the code used
for context switching. The VIS instruction determines which
enabled and pending interrupt has the highest priority, and
causes an indirect jump to the address corresponding to that
interrupt source. The jump addresses (vectors) for all possible interrupts sources are stored in a vector table.
The vector table may beas long as 32 bytes (maximum of16
vectors) and resides at the top of the 256-byte block containing the VIS instruction. However, if the VIS instruction is at
the very top of a 256-byte block (such as at 00FF Hex), the
vector table resides at the top of the next 256-byte block.
Thus, if the VIS instruction is located somewhere between
00FF and 01DF Hex (the usual case), the vector table is located between addresses 01E0 and 01FF Hex. If the VIS instruction is located between 01FF and 02DF Hex, then the
vector table is located between addresses 02E0 and 02FF
Hex, and so on.
Each vector is 15 bits long and points to the beginning of a
specific interrupt service routine somewhere in the 32 kbyte
memory space. Each vector occupies two bytes of thevector
table, with the higher-order byte at the lower address. The
vectors are arranged in order of interrupt priority. The vector
of the maskable interrupt with the lowest rank is located to
0yE0 (higher-order byte) and 0yE1 (lower-order byte). The
next priority interrupt is located at 0yE2 and 0yE3, and so
forth in increasing rank. The Software Trap has the highest
rank and its vector is always located at 0yFE and 0yFF.The
number of interrupts which can become active defines the
size of the table.
Table 10
shows the types of interrupts, the interrupt arbitration ranking, and the locations of the corresponding vectors
in the vector table.
The vector table should be filled by the user with the memory
locations of the specific interrupt service routines. For ex-
www.national.com39
Page 40
Interrupts (Continued)
ample, if the Software Trap routine is located at 0310 Hex,
then the vector location 0yFE and -0yFF should contain the
data 03 and 10 Hex, respectively. When a Software Trap interrupt occurs and the VIS instruction is executed, the program jumps to the address specified in the vector table.
The interrupt sources in the vector table are listed in order of
rank, from highest to lowest priority. If two or more enabled
and pending interrupts are detected at the same time, the
one with the highest priority is serviced first. Upon return
from the interrupt service routine, the next highest-level
pending interrupt is serviced.
If the VIS instruction is executed, but no interrupts are enabled and pending, the lowest-priority interrupt vector is
used, and a jump is made to the corresponding address in
the vector table. This is an unusual occurrence, and may be
the result of an error.It can legitimately result from a change
in the enable bits or pending flags prior to the execution of
the VIS instruction, such as executing a single cycle instruction which clears an enable flag at the same time that the
pending flag is set. It can also result, however,from inadvertent execution of the VIS command outside of the context of
an interrupt.
The default VIS interrupt vector can be useful for applications in which time critical interrupts can occur during the
gram context (A, B, X, etc.) and executing the RETI instruction, an interrupt service routine can be terminated by returning to the VIS instruction. In this case, interrupts will be
serviced in turn until no further interrupts are pending and
the default VIS routine is started. After testing the GIE bit to
ensure that execution is not erroneous, the routine should
restore the program context and execute the RETI to return
to the interrupted program.
This technique can save up to fifty instruction cycles (t
more, (50 µs at 10 MHz oscillator) of latency for pending in-
c
), or
terrupts with a penalty of fewer than ten instruction cycles if
no further interrupts are pending.
To ensure reliable operation, the user should always use the
VIS instruction to determine the source of an interrupt. Although it is possible to poll the pending bits to detect the
source of an interrupt, thispractice is not recommended. The
use of polling allows the standard arbitration ranking to be altered, but the reliability of the interrupt system is compromised. The polling routine must individually test the enable
and pending bits of each maskable interrupt. If a Software
Trap interrupt should occur, it will be serviced last, even
though it should have the highest priority. Under certain conditions, a Software Trap could be triggered but not serviced,
resulting in an inadvertent “locking out” of all maskable interrupts by the Software Trap pending flag. Problems such as
this can be avoided by using VIS instruction.
servicing of another interrupt. Rather than restoring the pro-
TABLE 10. Interrupt Vector Table
Arbitration Rank Interrupt Source Description Vector Address
1 Software Trap INTR Instruction 0yFE–0yFF
2 reserved NMI 0yFC–0yFD
3 CAN Receive RBF, RFV set 0yFA–0yFB
4 CAN Error TERR, RERR set 0yF8–0yF9
(transmit/receive)
5 CAN Transmit TBE set 0yF6–0yF7
6 Pin G0 Edge External 0yF4–0yF5
7 MICROWIRE/PLUS BUSY Goes Low 0yF2–0yF3
SPI Interface SRBF or STBE set
8 Timer T0 Idle Timer Underflow 0yF0–0yF1
9 UART receive buffer full 0yEE–0yEF
10 UART transmit buffer empty 0yEC–0yED
11 Timer T2 T2A/Underflow 0yEA–0yEB
12 Timer T2 T2B 0yE8–0yE9
13 Timer T1 T1A/Underflow 0yE6–0yE7
14 Timer T1 T1B 0yE4–0yE5
15 Port L, Port M; Port L Edge or 0yE2–0yE3
MIWU Port M Edge
16 Default VIS Interrupt VIS Interrupt 0yE0–0yE1
Note 27: yis a variable which represents the VIS block. VIS and the vector table must be located in the same 256-byte block except if VIS is located at the last address of a block. In this case, the table must be in the next block.
www.national.com 40
Page 41
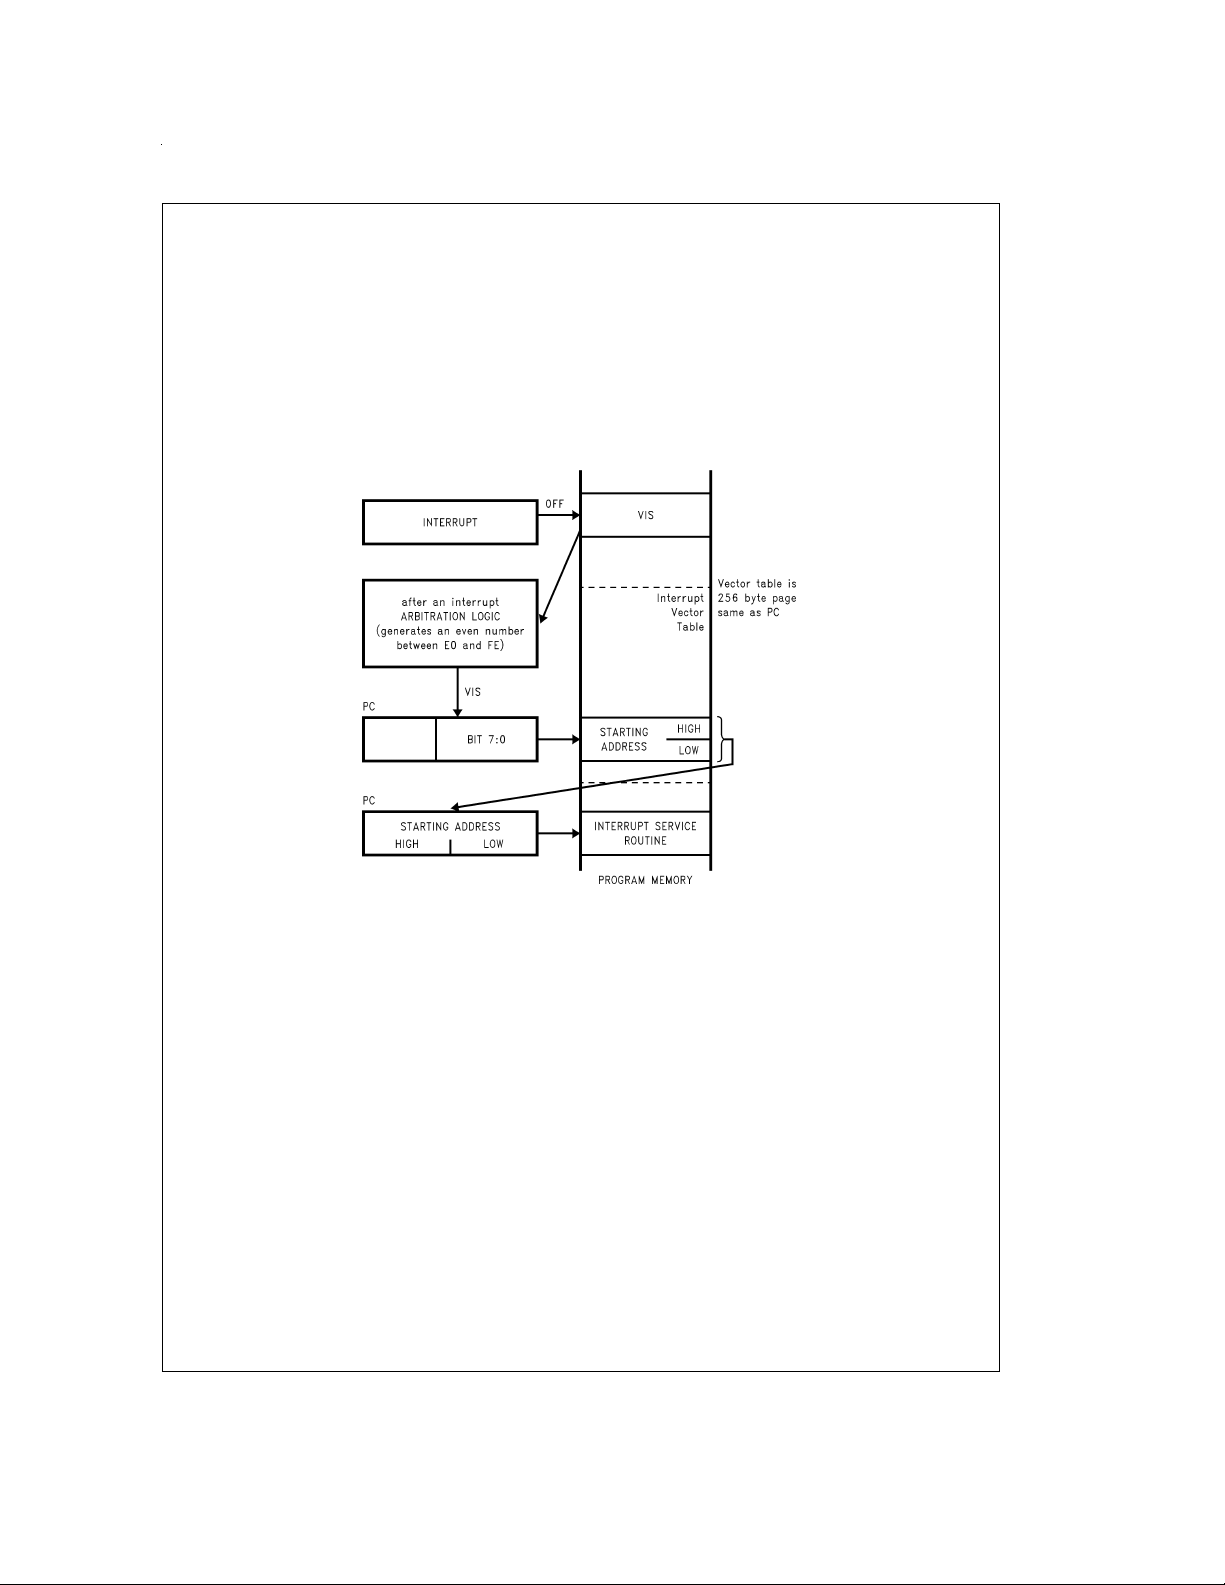
Interrupts (Continued)
VIS Execution
When the VIS instruction is executed it activates the arbitration logic. The arbitration logic generates an even number
between E0 and FE (E0, E2, E4, E6 etc...) depending on
which active interrupt has the highest arbitration ranking at
the time of the 1st cycle of VIS is executed. For example, if
the software trap interrupt is active, FE is generated. If the
external interrupt is active and the software trap interrupt is
not, then FAis generated and so forth. If the only active interrupt is software trap, than E0 is generated. This number replaces the lower byte of the PC. The upper byte of the PC re-
mains unchanged. The new PC is therefore pointing to the
vector of the active interrupt with the highest arbitration ranking. This vector is read from program memory and placed
into the PC which is now pointed to the 1st instruction of the
service routine of the active interrupt with the highest arbitration ranking.
Figure 32
instruction.
tion.
The non-maskable interrupt pending flag is cleared by the
RPND (Reset Non-Maskable Pending Bit) instruction (under
certain conditions) and upon RESET.
illustrates the different steps performed by the VIS
Figure 33
shows a flowchart for the VIS instruc-
FIGURE 32. VIS Operation
DS012837-29
www.national.com41
Page 42
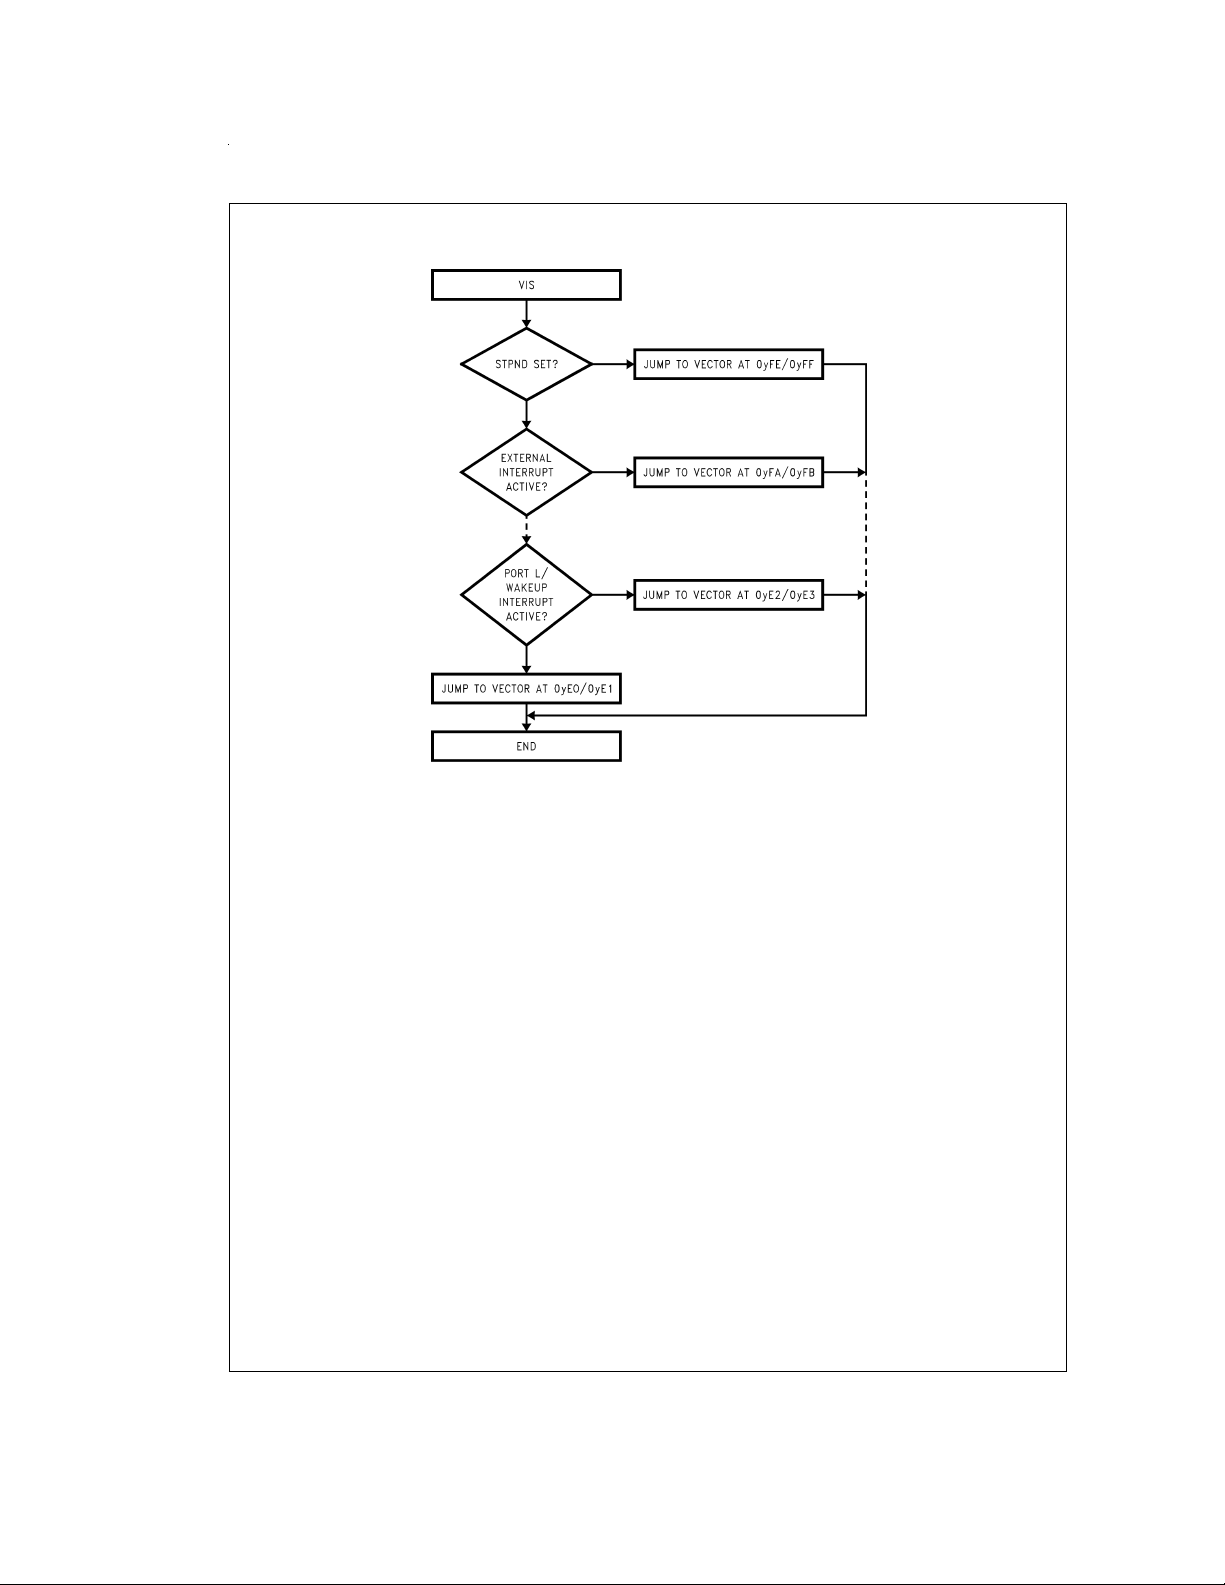
Interrupts (Continued)
DS012837-30
FIGURE 33. VIS Flowchart
www.national.com 42
Page 43

Interrupts (Continued)
Programming Example: External Interrupt
PSW =00EF
CNTRL =00EE
RBIT 0,PORTGC
RBIT 0,PORTGD ; G0 pin configured Hi-Z
SBIT IEDG, CNTRL ; Ext interrupt polarity; falling edge
SBIT EXEN, PSW ; Enable the external interrupt
WAIT: JP WAIT ; Wait for external interrupt
INT_EXIT:
SERVICE: RBIT EXPND, PSW ; Interrupt Service Routine
SBIT GIE, PSW ; Set the GIE bit
.
.
.
.=0FF ; The interrupt causes a
VIS ; branch to address 0FF
; The VIS causes a branch to
;interrupt vector table
.
.
.
.=01FA ; Vector table (within 256 byte
.ADDRW SERVICE ; of VIS inst.) containing the ext
; interrupt service routine
.
.
RETI
.
.
; Reset ext interrupt pend. bit
.
.
.
JP INT_EXIT ; Return, set the GIE bit
www.national.com43
Page 44
Interrupts (Continued)
NON-MASKABLE INTERRUPT
Pending Flag
There is a pending flag bit associated with the non-maskable
interrupt, called STPND. This pending flag is not memorymapped and cannot be accessed directly by the software.
The pending flag is reset to zero when a device Reset occurs. When the non-maskable interrupt occurs, the associated pending bit is set to 1. The interrupt service routine
should contain an RPND instruction to reset the pending flag
to zero. The RPND instruction always resets the STPND
flag.
Software Trap
The Software Trap is a special kind of non-maskable interrupt which occurs when the INTR instruction (used to acknowledge interrupts) is fetched from program memory and
placed in the instruction register. This can happen in a variety of ways, usually because of an error condition. Some examples of causes are listed below.
If the program counter incorrectly points to a memory location beyond the available program memory space, the nonexistent or unused memory location returns zeroes which is
interpreted as the INTR instruction.
If the stack is popped beyond the allowed limit (address 06F
Hex), a 7FFF will be loaded into the PC, if this last location in
program memory is unprogrammed or unavailable, a Software Trap will be triggered.
A Software Trap can be triggered by a temporary hardware
condition such as a brownout or power supply glitch.
The Software Trap has the highest priority of all interrupts.
When a Software Trap occurs, the STPND bit is set. The GIE
bit is not affected and the pending bit (not accessible by the
user) is used to inhibit other interrupts and to direct the program to the ST service routine with the VIS instruction. Nothing can interrupt a Software Trap service routine except for
another Software Trap. The STPND can be reset only by the
RPND instruction or a chip Reset.
The Software Trap indicates an unusual or unknown error
condition. Generally, returning to normal execution at the
point where the Software Trap occurred cannot be done reliably. Therefore, the Software Trap service routine should
reinitialize the stack pointer and perform a recovery procedure that restarts the software at some known point, similar
to a device Reset, but not necessarily performing all the
same functions as a device Reset.The routine must also execute the RPND instruction to reset the STPND flag. Otherwise, all other interrupts will be locked out.To the extent possible, the interrupt routine should record or indicate the
context of the device so that the cause of the Software Trap
can be determined.
If the user wishes to return to normal execution from the
point at which the Software Trap was triggered, the user
must first execute RPND, followed by RETSK rather than
RETI or RET. This is because the return address stored on
the stack is the address of the INTR instruction that triggered
the interrupt. The program must skip that instruction in order
to proceed with the next one. Otherwise, an infinite loop of
Software Traps and returns will occur.
Programming a return to normal execution requires careful
consideration. If the Software Trap routine is interrupted by
another Software Trap, the RPND instruction in the service
routine for the second Software Trap will reset the STPND
flag; upon return to the first Software Trap routine, the
STPND flag will have the wrong state. This will allow
maskable interrupts to be acknowledged during the servicing
of the first Software Trap. Toavoid problems such as this, the
user program should contain the Software Trap routine to
perform a recovery procedure rather than a return to normal
execution.
Under normal conditions, the STPND flag is reset by a
RPND instruction in the Software Trap service routine. If a
programming error or hardware condition (brownout, power
supply glitch, etc.) sets the STPND flag without providing a
way for it to be cleared, all other interrupts will be locked out.
To alleviate this condition, the user can use extra RPND instructions in the main program and in the WATCHDOG service routine (if present). There is no harm in executing extra
RPND instructions in these parts of the program.
PORT L INTERRUPTS
Port L provides the user with an additional eight fully selectable, edge sensitive interrupts which are all vectored into the
same service subroutine.
The interrupt from Port L shares logic with the wake up circuitry.The register WKEN allows interrupts from Port L to be
individually enabled or disabled. The register WKEDG specifies the trigger condition to be either a positive or a negative
edge. Finally, the register WKPND latches in the pending
trigger conditions.
The GIE (Global Interrupt Enable) bit enables the interrupt
function.
A control flag, LPEN, functions as a global interrupt enable
for Port L interrupts. Setting the LPEN flag will enable interrupts and vice versa. A separate global pending flag is not
needed since the register WKPND is adequate.
Since Port L is also used for waking the device out of the
HALTor IDLE modes, the user can elect to exit the HALTor
IDLE modes either with or without the interrupt enabled. If he
elects to disable the interrupt, then the device will restart execution from the instruction immediately following the instruction that placed the microcontroller in the HALT or IDLE
modes. In the other case, the device will first execute the interrupt service routine and then revert to normal operation.
(See HALT MODE for clock option wakeup information.)
INTERRUPT SUMMARY
The device uses the following types of interrupts, listed below in order of priority:
1. The Software Trap non-maskable interrupt, triggered by
the INTR (00 opcode) instruction. The Software Trap is
acknowledged immediately. This interrupt service routine can be interrupted only by another Software Trap.
The Software Trap should end with two RPND instructions followed by a restart procedure.
2. Maskable interrupts, triggered by an on-chip peripheral
block or an external device connected to the device. Under ordinary conditions, a maskable interrupt will not interrupt any other interrupt routine in progress. A
maskable interrupt routine in progress can be interrupted by the non-maskable interrupt request. A
maskable interrupt routine should end with an RETI instruction or, prior to restoring context, should return to
execute the VIS instruction. This is particularly useful
when exiting long interrupt service routiness if the time
between interrupts is short. Inthis case the RETI instruction would only be executed when the default VIS routine is reached.
www.national.com 44
Page 45
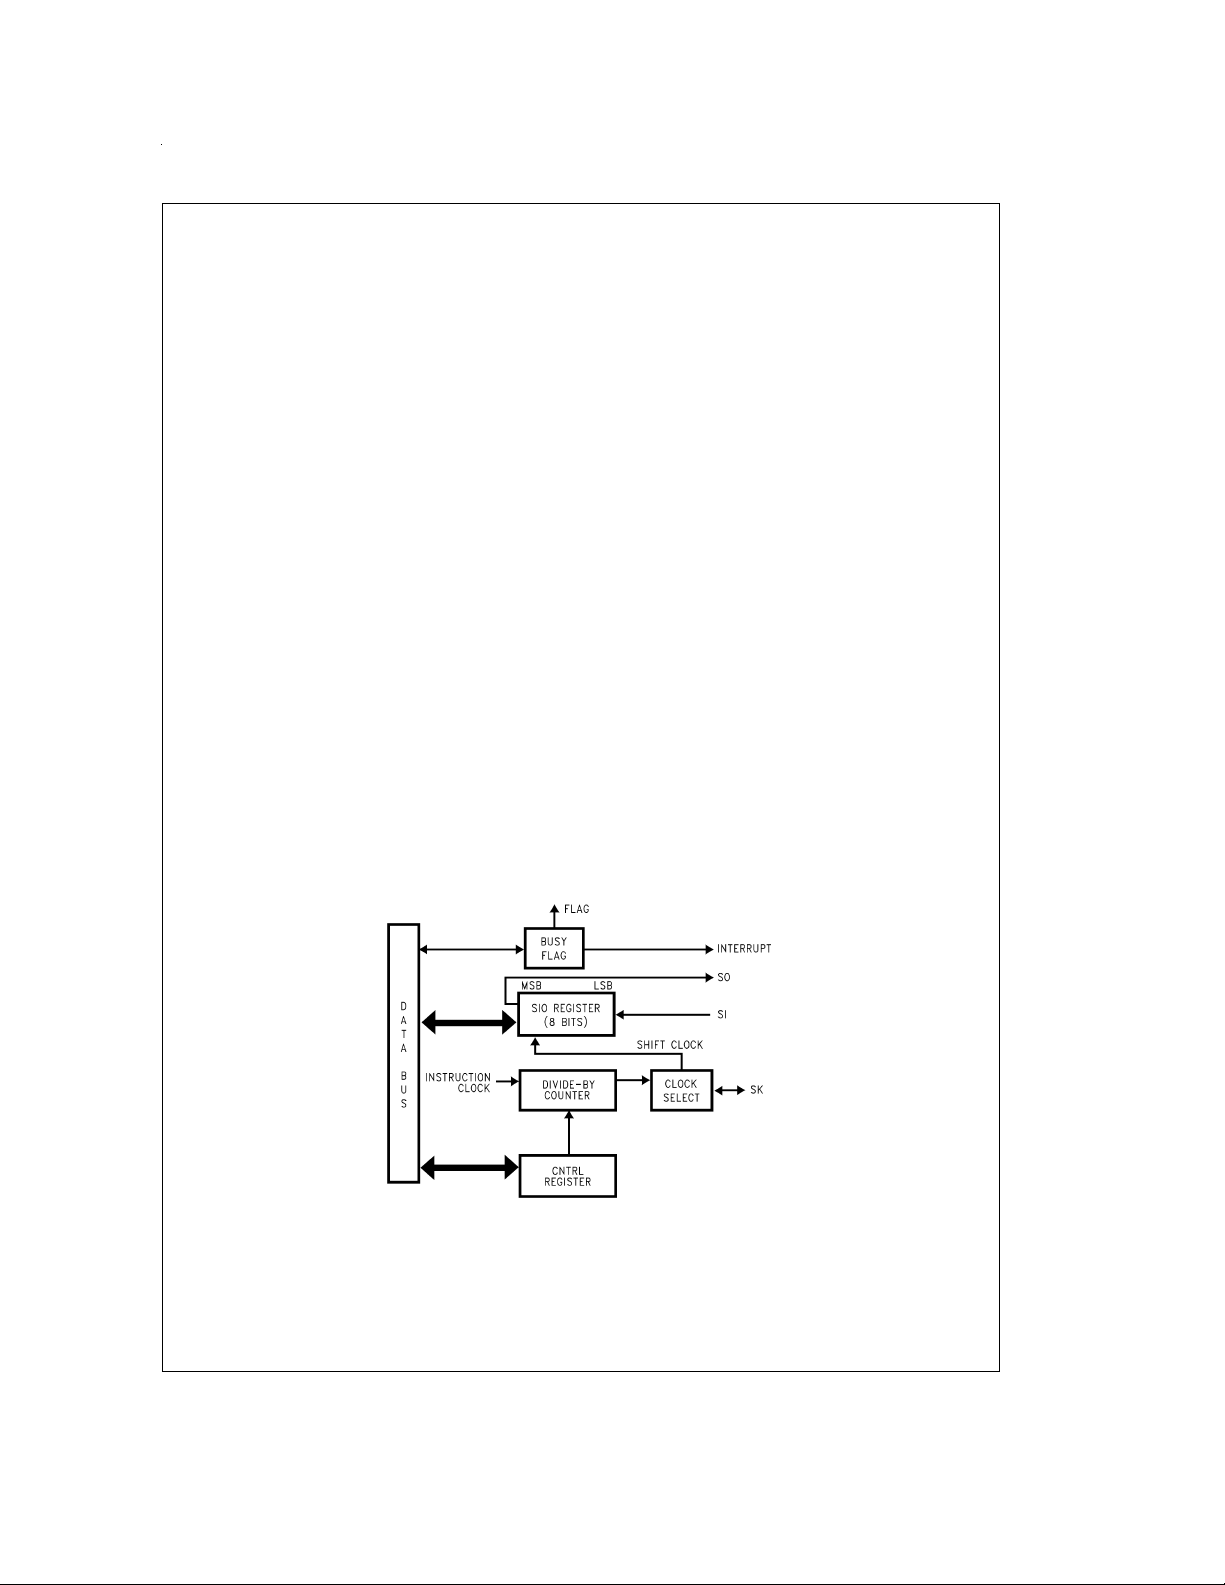
Detection of Illegal Conditions
The device can detect various illegal conditions resulting
from coding errors, transient noise, power supply voltage
drops, runaway programs, etc.
Reading of underfined ROM gets zeros. The opcode for software interrupt is zero. If the program fetches instructions
from undefined ROM, this will force a software interrupt, thus
signaling that an illegal condition has occurred.
The subroutine stack grows down for each call (jump to subroutine), interrupt, or PUSH, and grows up for each return or
POP. The stack pointer is initialized to RAM location 02FHex
during reset. Consequently, if there are more returns than
calls, the stack pointer will point to addresses 030 and 031
Hex (which are undefined RAM). Undefined RAM from address 030 to 03F Hex is read as all 1’s, which in turn will
cause the program to return to address 7FFF Hex. This is an
undefined ROM location and the instruction fetched (all 0’s)
from this location will generate a software interrupt signaling
an illegal condition.
Thus, the chip can detect the following illegal conditions:
1. Executing from undefined ROM.
2. Over “POP”ing the stack by having more returns than
calls.
When the software interrupt occurs, the user can re-initialize
the stack pointer and doa recovery procedure before restarting (this recovery program is probably similar to that following reset, but might not contain the same program initialization procedures).
MICROWIRE/PLUS
MICROWIRE/PLUS is a serial synchronouscommunications
interface. The MICROWIRE/PLUS capability enables the device to interface with any of National Semiconductor’s MICROWIRE peripherals (i.e., A/D converters, display drivers,
E2PROMs etc.) and with other microcontrollers which support the MICROWIRE interface. It consists of an 8-bit serial
shift register (SIO) with serial data input (SI), serial data output (SO) and serial shift clock (SK).
diagram of the MICROWIRE/PLUS logic.
The shift clock can be selected from either an internal source
or an external source. Operating the MICROWIRE/PLUS arrangement with the internal clock source is called the Master
mode of operation. Similarly, operating the MICROWIRE/
PLUS arrangement with an external shift clock is called the
Slave mode of operation.
The CNTRL register is used to configure and control the
MICROWIRE/PLUS mode. To use the MICROWIRE/PLUS,
the MSEL bit in the CNTRL register is set to one. In the master mode the SK clock rate is selected by the two bits, SL0
and SL1, in the CNTRL register.
clock rates that may be selected.
MICROWIRE/PLUS OPERATION
Setting the BUSY bit in the PSW register causes the
MICROWIRE/PLUS to start shifting the data. It gets reset
when eight data bits have been shifted. The user may reset
the BUSY bit by software to allow less than 8 bits to shift. If
enabled, an interrupt is generated when eight data bits have
been shifted. The device may enter the MICROWIRE/PLUS
mode either as a Master or as a Slave.
two COP888 family microcontrollers and several peripherals
may be interconnected using the MICROWIRE/PLUS arrangements.
WARNING:
The SIO register should only be loaded when the SK clock is
low. Loading the SIO register while the SK clock is high will
result in undefined data in the SIO register. SK clock is normally low when not shifting.
Setting the BUSY flag when the input SK clock is high in the
MICROWIRE/PLUS slave mode may cause the current SK
clock for the SIO shift register to be narrow. For safety, the
BUSY flag should only be set when the input SK clock is low.
Figure 34
Table11
Figure 34
shows a block
details the different
shows how
FIGURE 34. MICROWIRE/PLUS Block Diagram
DS012837-36
www.national.com45
Page 46

MICROWIRE/PLUS (Continued)
FIGURE 35. MICROWIRE/PLUS Application
MICROWIRE/PLUS Master Mode Operation
In the MICROWIRE/PLUS Master mode of operation the
shift clock (SK) is generated internally. The MICROWIRE
Master always initiates all data exchanges. The MSEL bit in
the CNTRL register must be set to enable the SO and SK
functions onto the G Port. The SO and SK pins must also be
selected as outputs by setting appropriate bits in the Port G
configuraiton register.
required for Master or Slave mode of operation.
TABLE 11. MICROWIRE/PLUS Master Mode
SL1 SL0 SK
0 0 2Xt
0 1 4Xt
1 x 8Xt
Where tcis the instruction cycle clock
MICROWIRE/PLUS Slave Mode Operation
In the MICROWIRE/PLUS Slave mode of operation the SK
clock is generated by an external source. Setting the MSEL
bit in the CNTRL register enables the SO and SK functions
onto the G Port. The SK pin must be selected as an input
and the SO pin is selected as an output pin by setting and resetting the appropriate bit in the Port G configuration register.
Table 3
summarizes the settings required to enter the
Slave mode of operation.
The user must set the BUSY flag immediately upon entering
the Salve mode. This will ensure that all data bits sent by the
Master will be shifted properly. After eight clock pulses the
BUSY flag will be cleared and the sequence may be repeated.
Table 12
summarizes the bit settings
Clock Selection
c
c
c
DS012837-37
Alternate SK Phase Operation
The device allows either the normal SK clock or an alternate
phase SK clock to shift data in and out of the SIO register.In
both the modes the SK is normally low. In the normal mode
data is shifted in on the rising edge of the SK clock and the
data is shifted out on the falling edge of the SK clock. The
SIO register is shifted on each falling edge of the SK clock in
the normal mode. In the alternate SK phase mode the SIO
register is shifted on the rising edge of the SK clock.
A control flag, SKSEL, allows either the normal SK clock or
the alternate SK clock to be selected. Resetting SKSEL
causes the MICROWIRE/PLUS logic to be clocked from the
normal SK signal. Setting the SKSEL flag selects the alternate SK clock. The SKSEL is mapped into the G6 configuration bit. The SKSEL flag will power up in the reset condition,
selecting the normal SK signal.
TABLE 12. MICROWIRE/PLUS Mode Selection
This table assumes that the control flag MSEL is set.
G4 G5
(SO) (SK)
Config. Config.
G4
Fun.
G5
Fun.
Operation
Bit Bit
1 1 SO Int. SK MICROWIRE/
PLUS Master
0 1 TRI-STATE Int. SK MICROWIRE/
PLUS Master
1 0 SO Ext. SK MICROWIRE/
PLUS Slave
0 0 TRI-STATE Ext. SK MICROWIRE/
PLUS Slave
www.national.com 46
Page 47
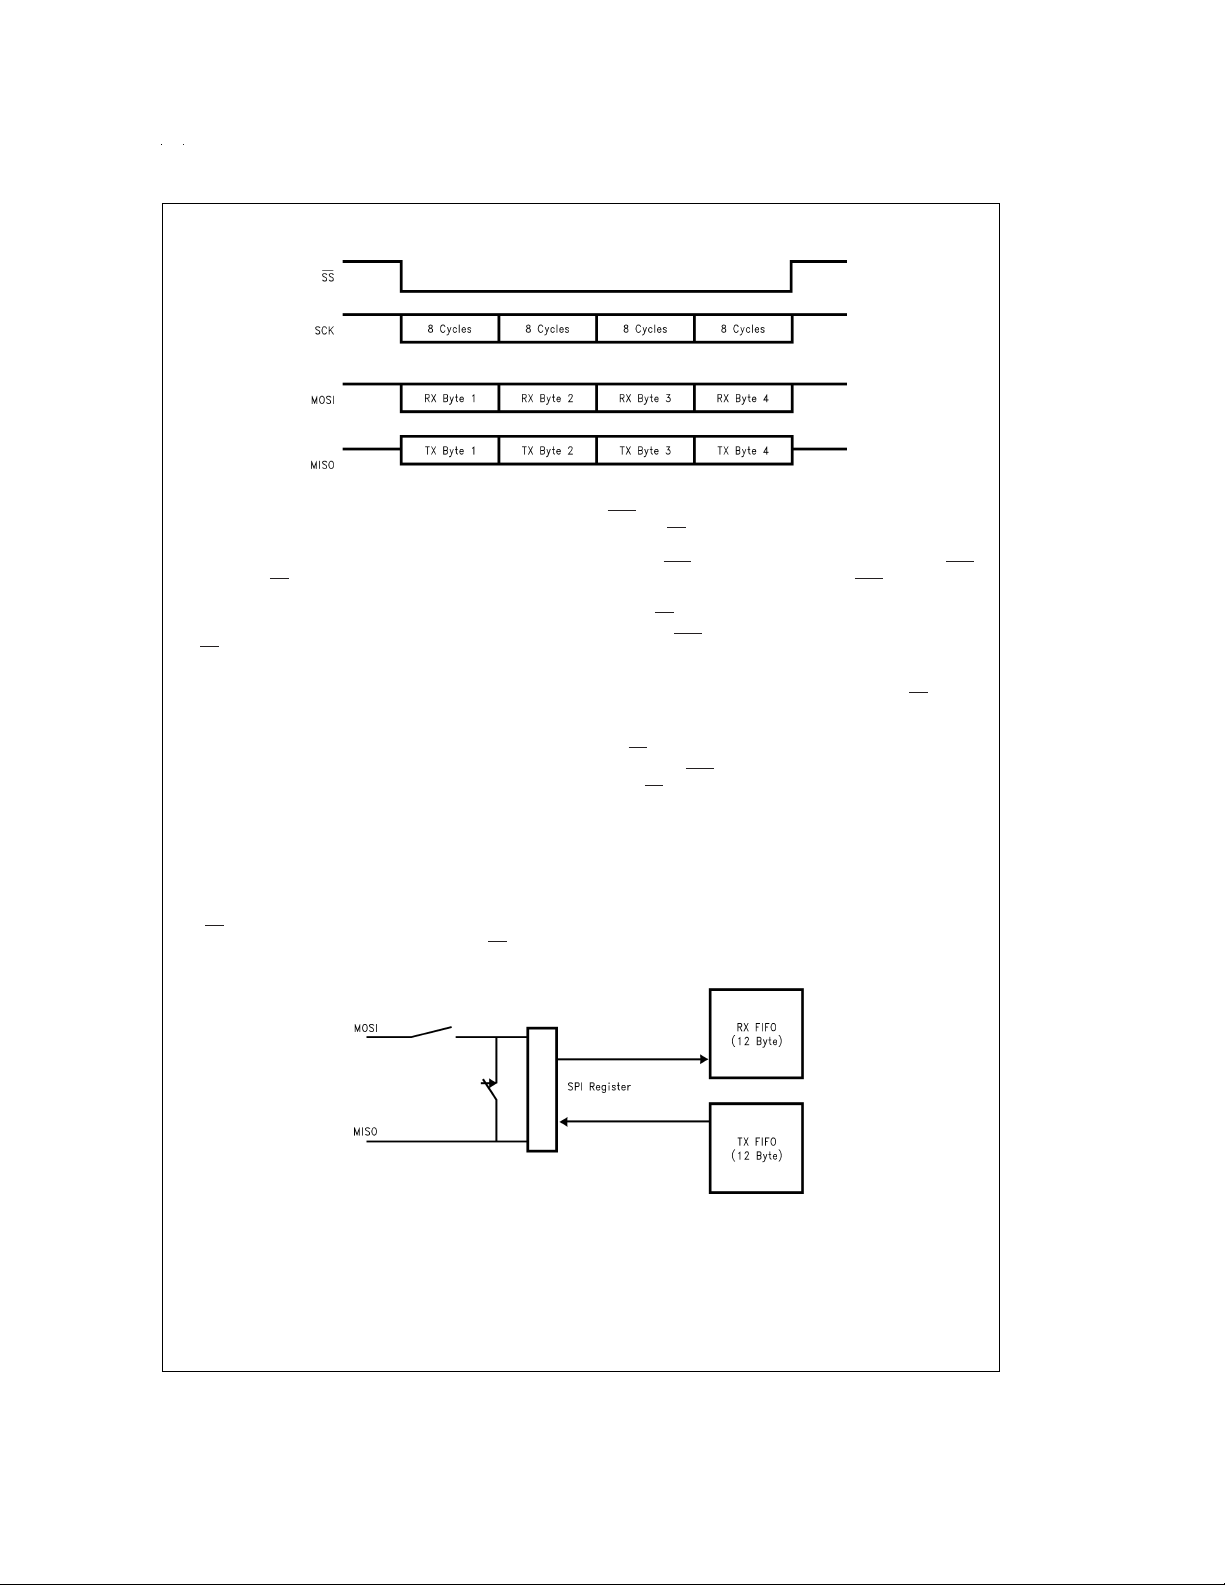
Serial Peripheral Interface
FIGURE 36. SPI Transmission Example
The Serial Peripheral Interface (SPI) is used in master-slave
bus systems. It is a synchronous bidirectional serial communication interface with two data lines MISO and MOSI (Master In Slave Out, Master Out Slave In). A serial clock and a
slave select (SS) signal are always generated by the SPI
Master. The interface receives/transmits protocol frames
with up to 12 bytes length within a frame, where a frame is
defined as the time between a falling edge and a rising edge
of SS.
THEORY OF OPERATION
Figure 38
tion of the SPI circuit. In the SPI interface, data is
transmitted/received in packets of 8 bits length which are
shifted into/out of a shift register with the active edge of the
shift clock SCK. Two 12 byte FIFOs, which serve as a receive and a transmit buffer, allow a maximum message
length of 12 x 8 bits in both transmit and receive direction
without CPU intervention. With CPU intervention, many
more bytes can be received. Two registers, the SPI Control
Register (SPICNTL) and the SPI Status Register (SPISTAT),
are used to control the SPI interface via the internal COP
bus. Several different operation modes, such as master or
slave operation, are possible.
An SS-Expander allows the generation of up to 8 signals on
the N-port, which can be used as additional SS-signals
shows a block diagram illustrating the basic opera-
DS012837-38
(ESS[7:0]) or as host programmable general purpose signals. The SS-Expander is programmed with the content of
the first MOSI-byte (i.e., the content of the 1st byte [7:0] appears at ESS[7:0]) (N-port[7:0]), respectively), if the ESS
programming mode is selected. The ESS programming
mode is selected by the condition MOSI = L at the falling
edge of SS.
Use of the ESS expander requires the setup of four conditions by the user.
1. Set the SESSEN bit of SPICNTL.
2. Set PORTNX to select which bits are used forSS expansion.
3. Configure the PORTNC register to enable the desired
SS expansion bits as outputs.
4. Have an ESS condition (MOSI = low at the falling edge
of SS).
Loop Back Mode
Setting the SLOOP bit enables the Loop Back mode, which
can be used for test purposes. If the Loop Back mode is selected, TX FIFO data are communicated to the RX FIFO via
the SPI Register. In the slave mode, MISO output is internally connected to the MOSI input. In the master mode, the
MOSI output is internally connected to the MISO input.
FIGURE 37. Loop Back Mode Block Diagram
DS012837-39
www.national.com47
Page 48
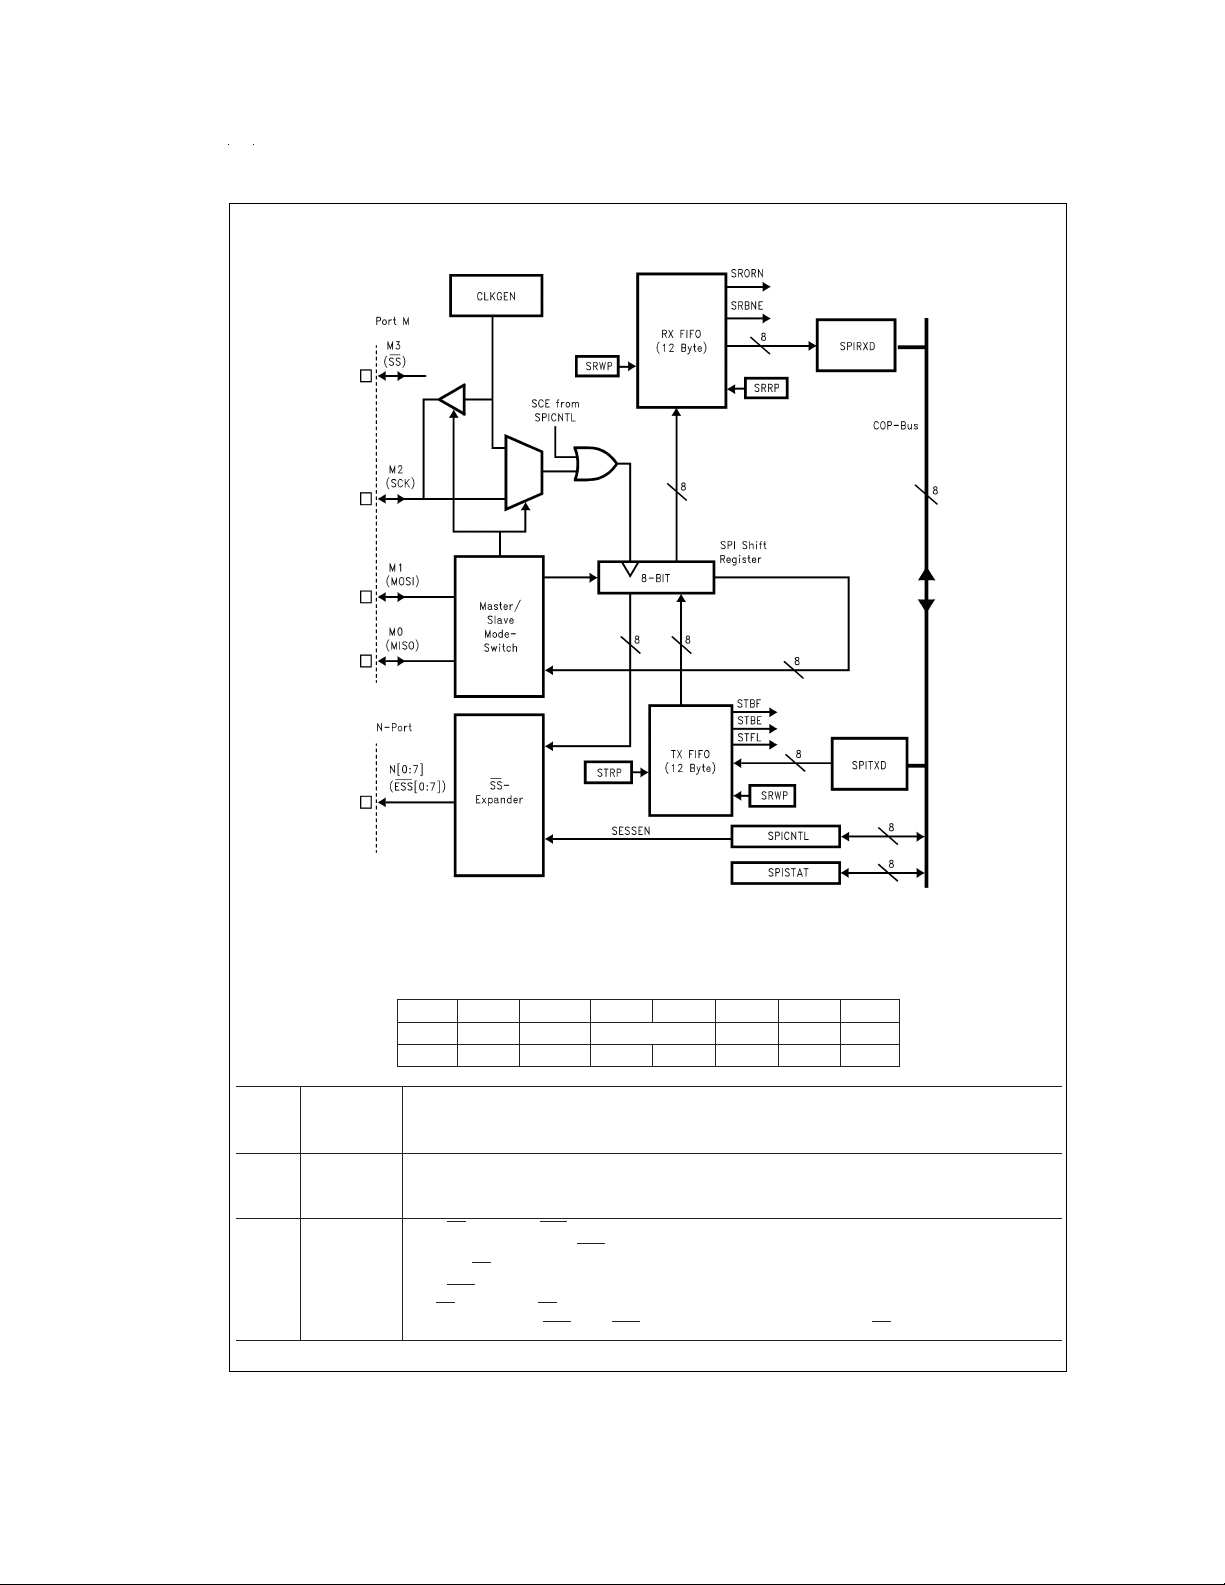
Serial Peripheral Interface (Continued)
FIGURE 38. SPI Block Diagram
The SPIU Control Register
TABLE 13. SPI Control (SPICNTL) (0098)
Bit 7 Bit 6 Bit 5 Bit 4 Bit 3 Bit 2 Bit 1 Bit 0
SRIE STIE SESSEN SPIMOD[1:0] SCE SPIEN SLOOP
00 0 00000
B7 SRIE SPI Receive Interrupt Enable
0— disable receive interrupt
0— enable receive interrupt
B6 STIE SPI Transmit buffer Interrupt Enable
0— disable transmit buffer interrupt
0— enable transmit buffer interrupt
B5 SESSEN SPI SS Expander (ESS) enable
0— The detection of the ESS programming mode is disabled, i.e., the value of MOSI at the falling
edge of SS is “don’t care”.
1— ESS programming mode detection is enabled, i.e., if the condition “MOSI=0atthefalling edge
of SS” occurs, the SS-Expander is selected and bits [7:0] of the first transmitted byte determine the
state of the N-port (ESS[7:0]). ESS[7:0] will go 1 at the positive edge of SS.
www.national.com 48
DS012837-40
Page 49
Serial Peripheral Interface (Continued)
B[4:3] SPIMOD[1:0] SPI operation mode select
SPIMOD[1:0]
0 0: Slave mode,
—SCK is SPI clock input
—MISO is SPI data output
—MOSI is SPI data input
—SS is slave select input
1 0: Standard Master mode,
—SCK is SPI clock output (CKI/40)
—MISO is SPI data input
—MOSI is SPI data output
—SS is slave select output
In the Master mode, 3 different SPI clock frequencies are available:
01:f
10:f
11:f
B2 SCE SPI active clock edge select
0: data are shifted out on the falling edge of SCK and are shifted in on the rising edge of SCK
1: data are shifted out on the rising edge of SCK and are shifted in on the falling edge of SCK
B1 SPIEN SPI enable
Enables the SPI interface and the alternate functions of the MISO, MOSI, SCK and SS pins.
0: disable SPI
1: enable SPI, all Port M ESS signals are set to 1
B0 SLOOP SPI loop back mode
0: disable loop back mode
1: enable loop back mode, MISO and MOSI are internally connected (see
= 1/(tc) = CKI/10
SCK
= 1/(4 tc) = CKI/40
SCK
= 1/(16 tc) = CKI/160
SCK
Figure 39
)
PROGRAMMING THE SPI EXPANDER
If the SS Expander is enabled by setting SESSEN=1inthe
SPI Control Register (SPICNTL), the N-port will be programmed with the content of the first MOSI-byte (i.e., the
content of the 1st byte [7:0] appears at N-port[7:0] after complete reception of the first byte), if the ESS programming
mode is detected. If any bytes follow after the 1st MOSI byte,
all data will be ignored by the SPI.
The ESS programming mode is detected by the ESS control
logic, which decodes the condition “MOSI = L at the falling
edge of SS. For further details, see
Figure 39
.
The selected N-port bits will be set to 1 after the positive
edge of SS.
Single N-port bits may be enabled for use as SS expansion,
or disabled to allow for general purpose I/O, by the respective bits in the PORTNX register.
www.national.com49
Page 50
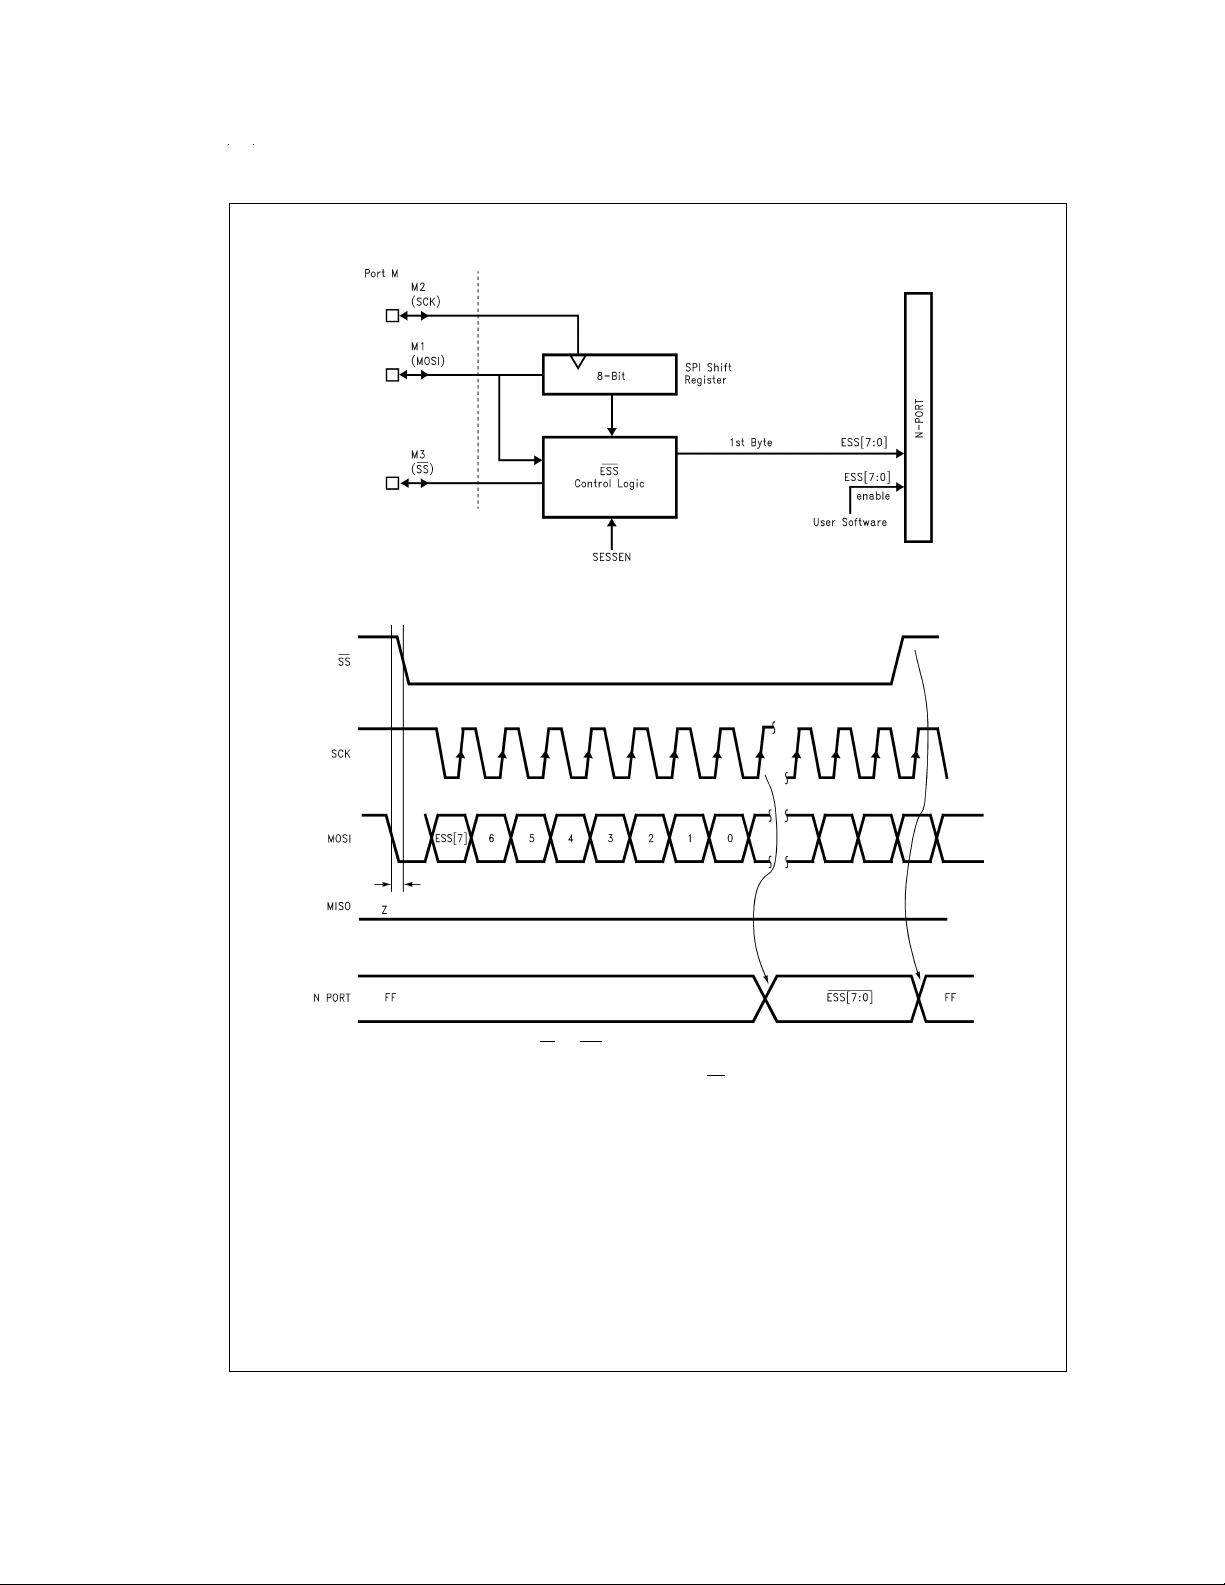
Serial Peripheral Interface (Continued)
FIGURE 39. Programming the SPI Expander
DS012837-41
SESSEN = 1, SCE = 0. If MOSI=0atthefalling edge of SS, the ESS programming
mode is detected and all N-port alternate functions are enabled.
FIGURE 40. Programming the SS Expander
www.national.com 50
DS012837-42
Page 51

SPI Status Register
a) Slave mode; rising SCK edge is active edge. (SPIMOD[1,0] = [0,0], SCE = 0)
b) Slave mode; falling SCK edge is active edge. (SPIMOD[1,0] = [0,0], SCE = 1)
FIGURE 41. Slave Mode Communication
a) Master mode; rising SCK edge is active edge. (SPIMOD[1,0] = [1,0], SCE = 0)
DS012837-43
DS012837-44
DS012837-45
b) Master mode; falling SCK edge is active edge. (SPIMOD[1,0] = [1,0], SCE = 1)
FIGURE 42. Master Mode Communication
DS012837-46
www.national.com51
Page 52
SPI Status Register (Continued)
TABLE 14. SPI Status Register (SPISTAT) (0099)
Bit 7 Bit 6 Bit 5 Bit 4 Bit 3 Bit 2 Bit 1 Bit 0
SRORN SRBNE STBF STBE STFL SESSDET x x
00110 0 0
The SPI Status Register is a read only register.
B7 SRORN SPI receiver overrun.
This bit is set on the attempt to overwrite valid data in the RX FIFO by the SPI interface. (The condition to
detect this is: SRWP = SRRP & COP has not read the data at SRRP and attempting to write to the RX FIFO
by the SPI interface.) This bit can generate a receive interrupt if the receive interrupt is enabled (SRIE = 1).
(Notes 28, 29, 30)
B6 SRBNE SPI Receive buffer not empty
This bit is set with a write to the SPI RX FIFO resulting in SRWP ! = SRRP (caution at rollover!). This bit is
reset with the read of the SPIRXD register resulting in SRWP to be equal to SRRP.
B5 STBF This bit can generate a receive interrupt if enabled with the RIE bit.
SPI Transmit buffer full
This bit is set after a write operation to the SPITXD register (from the COP side), which results in STRP =
STWP. It gets reset as soon as the STRP gets incremented - by the SPI if reading data out of the TX FIFO.
B4 STBE SPI transmit buffer empty
This bit is set after the last bit of the a read from the SPITXD register, which results in STRP = STWP. It gets
reset as soon as the STWP gets incremented - by the COP if writing data into the TX FIFO. It is set on reset.
B3 STFL SPI Transmit buffer flush
This bit indicates that the contents of the transmit buffer got discharged by the SS signal becoming high
before all data in the transmit buffer could be transmitted. This bit gets set if the SS signal gets high and
1.STRP ! = STWP or
2.STRP = STWP and the current byte has not been completely transmitted from the SPI shift register
These conditions will reset STRP and STWP to 0. These are virtual pointers and cannot be viewed. (Note 31)
B2 SESSDET SPI SS Expander detection
This bit indicates the detection of a SS expand condition (MOSI=0atthefalling edge of SS) immediately
after the N-port has been programmed (8th SCK bit, 8 µs at SCK = 1 MHz).
This bit is reset at the rising edge of SS.
1: SS expand condition detected.
0: normal communication. (Note 32)
B1 Reserved
B0 Reserved
Note 28: At this condition the write operation will not be executed and all data get lost.
Note 29: The SRORN bit stays set until the reset condition.
This bit is reset with a dummy write to the SPISTAT register. (As the register is read only a dummy write does not have any effect on any other bits in this register.)
As a result of the SRORN condition, the SRWP becomes frozen (i.e., does not change until the SRORN bit is reset) and the SPI will not store any new data in the
RX FIFO.
Note 30: With the SRRP being still available, the user can read the data in the RX FIFO before resetting the SRORN bit.
Note 31: STRP= STWP & STBE = 1 will generate an interrupt.
This bit gets reset with a write to the SPITXD register.
Note 32: The SPI master must hold SS = 0 long enough to allow the device to read SESSDET. Otherwise the SESSDET information will get lost.
www.national.com 52
Page 53
SPI Status Register (Continued)
SPI SYNCHRONIZATION
After the SPI is enabled (SPIEN = 1), the SPI internal receive and transmit shift clock is kept disabled until SS becomes inactive. This includes SS being active at the time
SPIEN is set, i.e., no receive/transmit is possible until SS
becomes inactive after enabling the SPI.
HALT/IDLE MODE
If the device enters the HALT/IDLEmode, both RX and TX
FIFOs get reset (Flushed). If the device is exiting HALT/
IDLE mode, and SPI synchronization takes place as described above. SPIRXD and SPITXD have the same state
as after Reset, SPISTAT bits after HALT/IDLE mode are:
SRORN: unchanged
SRBNE: 0
STBF: 0
STBE: 1
STFL: 1
SESSDET: x (depending on SS and MOSI line)
TRANSMISSION START IN MASTER MODE
The transmission of data in the Master mode is started if
the user controlled SS signal is switched active. No SCK
will be generated in Master mode and thus no data is
transmitted if the SS signal is kept high, i.e., SS must be
switched low to generate SCK. Resetting the SS signal in
the Master mode will immediately stop the transmission
and flush the transmit FIFO. Thus, the user must only reset the SS if:
1. TBE is set or
2. SCK is high (SCE = 0) or low (SCE = 1)
TX AND RX FIFO
If the SPI is disabled (SPIEN = 0), all SPI FIFO related
pointers are reset and kept at zero until the SPI is enabled
again.Also, the Read/Write operation to both SPITXD and
SPIRXD will not cause the pointers to change, if SPIEN is
set, Read operations from the RXFIFO and Write operation to TXFIFO will increment the respective Read/Write
pointers.
SPIRXD SPI Receive Data Register
SPIRXD is at address location “009A”. It is a read/write
register.
This register holds the receive data at the current SRRP
location: a COP read operation from thisregister to the accumulator will read the RX FIFO at the SRRP location and
increment SRRP afterwards. Awrite to this register (by the
controllers SW) will write to the RX FIFO at the current
SRRP location. The SRRP is not changed.
Note: During breakpoint the SRRP is not incremented.
Awrite to this register from the SPI interface side will write to
the current SRWP location and increment SRWP afterwards.
SPITXD SPI Transmit Data Register
SPITXD is at address location “009B”. It is a read/write register.
This register holds the transmit data at the current STWP location: a write from the controller to this register will write to
the STWP location and increment the STWP afterwards. A
read from the controller to this register will read the TX FIFO
at the current STWP location. The pointer is not changed.
Writing data into this register will start a transmission of data
in the master mode.
Note: No read modify write instructions should be used on this register.
Reading this register from the SPI side will read the byte at
the current STRP location and afterwards increment STRP.
SPI RX FIFO
The SPI RX FIFO is a 12 byte first in first out buffer. SPI RX
FIFO data are read from the controller by reading the
SPIRXD register. A pointer (SRRP) controls the controller
read location. Data is written to this register by the SPI interface. The write location is controlled by the SRWP. SRWP is
incremented after data is stored to the FIFO SRWP is never
decremented SRWP has a roll-over 10→11→0→1
2→etc. It is a circularly linked list.
SRRP is incremented after data is read from the FIFO SRRP
is never decremented SRRP has a roll-over 10→11→0
1→2→etc. It is a circularly linked list.
Both pointers are cleared at reset.
The following bits indicate the status of the RX FIFO:
SRBNE = (SRWP != SRRP) and !SRORN .SRORN is set at
(SRWP = SRRP) and after a write from the SPI side, reset at
write to SPISTAT.
Special conditions: if .SRORN is set, no writes to the RX
FIFO are allowed from the SPI side. SRWP is frozen. Resetting. SRORN (after it was set) clears both SRWP and SRRP.
To prevent erroneous clearing of the Receive FIFO when entering HALT/IDLE mode, the user needs to enable the MIWU
or port M3 (SS) by setting bit 3 in MWKEN register.
SPI TX FIFO
The SPI TX FIFO is a 12 byte first in first out buffer. Data is
written to the FIFO by the controller executing a write instruction to the SPITXD register. A pointer (STWP) controls the
controller write location. Data is read from this register by the
SPI interface. The read location is controlled by the STRP.
STRP is incremented after data is read from the FIFO STRP
is never decremented STRP has a roll-over 10→11→0
1→2→etc. It is a circularly linked list.
STWP is incremented after data is written to the FIFO STWP
is never decremented STWP has a roll-over 10→11→0
1→2→etc. It is a circularly linked list.
Both pointers are cleared at reset.
The following bits indicate the status of the TX FIFO: STBF
= set at (STRP = STWP) after a write from the controller reset at ((STRP != STWP) I STBE) after a read from the SPI
STBE = (STRP = STWP) after a read from the SPI.
Special conditions: If the SS signal becomes high before
data the last bit of the last byte in the TX FIFO is transmitted
both STRP and STWP will be set to 0. The STFL bit will be
set. (STBE will be set as well.)
Note: The SRRP,SRWP,STRP and STWP registers are not available to the
user. Their operation description is included for clarity and to enhance
the user’s understanding.
A/D Converter
The device contains an 8-channel, multiplexed input, successive approximation, Analog-to Digital converter. The device’s V
and GND pins are used for voltage reference.
CC
→
→
→
→
www.national.com53
Page 54
A/D Converter (Continued)
OPERATING MODES
The A/D converter supports ratiometric measurements. It
supports both Single Ended and Differential modes of operation.
Four specific analog channel selection modes are supported. These are as follows:
Allow any specific channel to be selected at one time. The
A/D converter performs the specific conversion requested
and stops.
Allow any specific channel to be scanned continuously. In
other words, the user specifies the channel and the A/D converter scans it continuously. At any arbitrary time the user
can immediately read the result of the last conversion. The
user must wait for only the first conversion to complete.
Allow any differential channel pair to be selected at one time.
The A/D converter performs the specific differential conversion requested and stops.
Allow any differential channel pair to be scanned continuously.In other words, the user specifies the differential channel pair and the A/D converter scans it continuously. At any
arbitrary time the user can immediately read the result of the
last differential conversion. The user must wait for only the
first conversion to complete.
TheA/D converter is supported by two memory mapped registers, the result register and the mode control register.
When the device is reset, the mode control register (ENAD)
is cleared, the A/D is powered down and the A/D result register has unknown data.
A/D Control Register
The ENAD control register contains 3 bits for channel selection, 2 bits for prescaler selection, 2 bits for mode selection
and a Busy bit. An A/D conversion is initiated by setting the
ADBSY bit in the ENAD control register. The result of the
conversion is available to the user in the A/D result register,
ADRSLT, when ADBSY is cleared by the hardware on
completion of the conversion.
ENAD (Address 0xCB)
CHANNEL MODE PRESCALER BUSY
SELECT SELECT SELECT
ADCH2 ADCH1 ADCH0 ADMOD1 ADMOD0 PSC1 PSC0 ADBSY
Bit 7 Bit 0
CHANNEL SELECT
This 3-bit field selects one of eight channels to be the V
The mode selection determines the V
input.
IN−
Single Ended mode:
Bit 7 Bit 6 Bit 5 Channel No.
000 0
001 1
010 2
011 3
100 4
101 5
110 6
111 7
IN+
Differential mode:
Bit 7 Bit 6 Bit 5 Channel Pairs (+, −)
000 0,1
001 1,0
010 2,3
011 3,2
100 4,5
101 5,4
110 6,7
111 7,6
MODE SELECT
This 2-bit field is used to select the mode of operation (single
conversion, continuous conversions, differential, single
ended) as shown in the following table.
Bit 4 Bit 3 Mode
0 0 Single Ended mode, single
conversion
0 1 Single Ended mode, continuous scan
of a single channel into the result
register
1 0 Differential mode, single conversion
1 1 Differential mode, continuous scan of
a channel pair into the result register
PRESCALER SELECT
This 2-bit field is used to select one of the four prescaler
clocks for the A/D converter. The following table shows the
various prescaler options.
A/D Converter Clock Prescale
Bit 2 Bit 1 Clock Select
0 0 Divide by 2
0 1 Divide by 4
1 0 Divide by 6
1 1 Divide by 12
BUSY BIT
The ADBSY bit of the ENAD register is used to control starting and stopping of the A/D conversion. When ADBSY is
cleared, the prescale logic is disabled and the A/D clock is
turned off. Setting theADBSY bit starts the A/D clock and initiates a conversion based on the mode select value currently
.
in the ENAD register. Normal completion of an A/D conversion clears the ADBSY bit and turns off the A/D converter.
TheADBSY bit remains a one during continuous conversion.
The user can stop continuous conversion by writing a zero to
the ADBSY bit.
If the user wishes to restart a conversion which is already in
progress, this can be accomplished only by writing a zero to
the ADBSY bit to stop the current conversion and then by
writing a one to ADBSY to start a new conversion. This can
be done in two consecutive instructions.
ADC Operation
The A/D converter interface works as follows. Setting the
ADBSY bit in the A/D control register ENAD initiates an A/D
conversion. The conversion sequence starts at the beginning of the write to ENAD operation which sets ADBSY, thus
powering up theA/D. At the first falling edge of the converter
clock following the write operation, the sample signal turns
www.national.com 54
Page 55
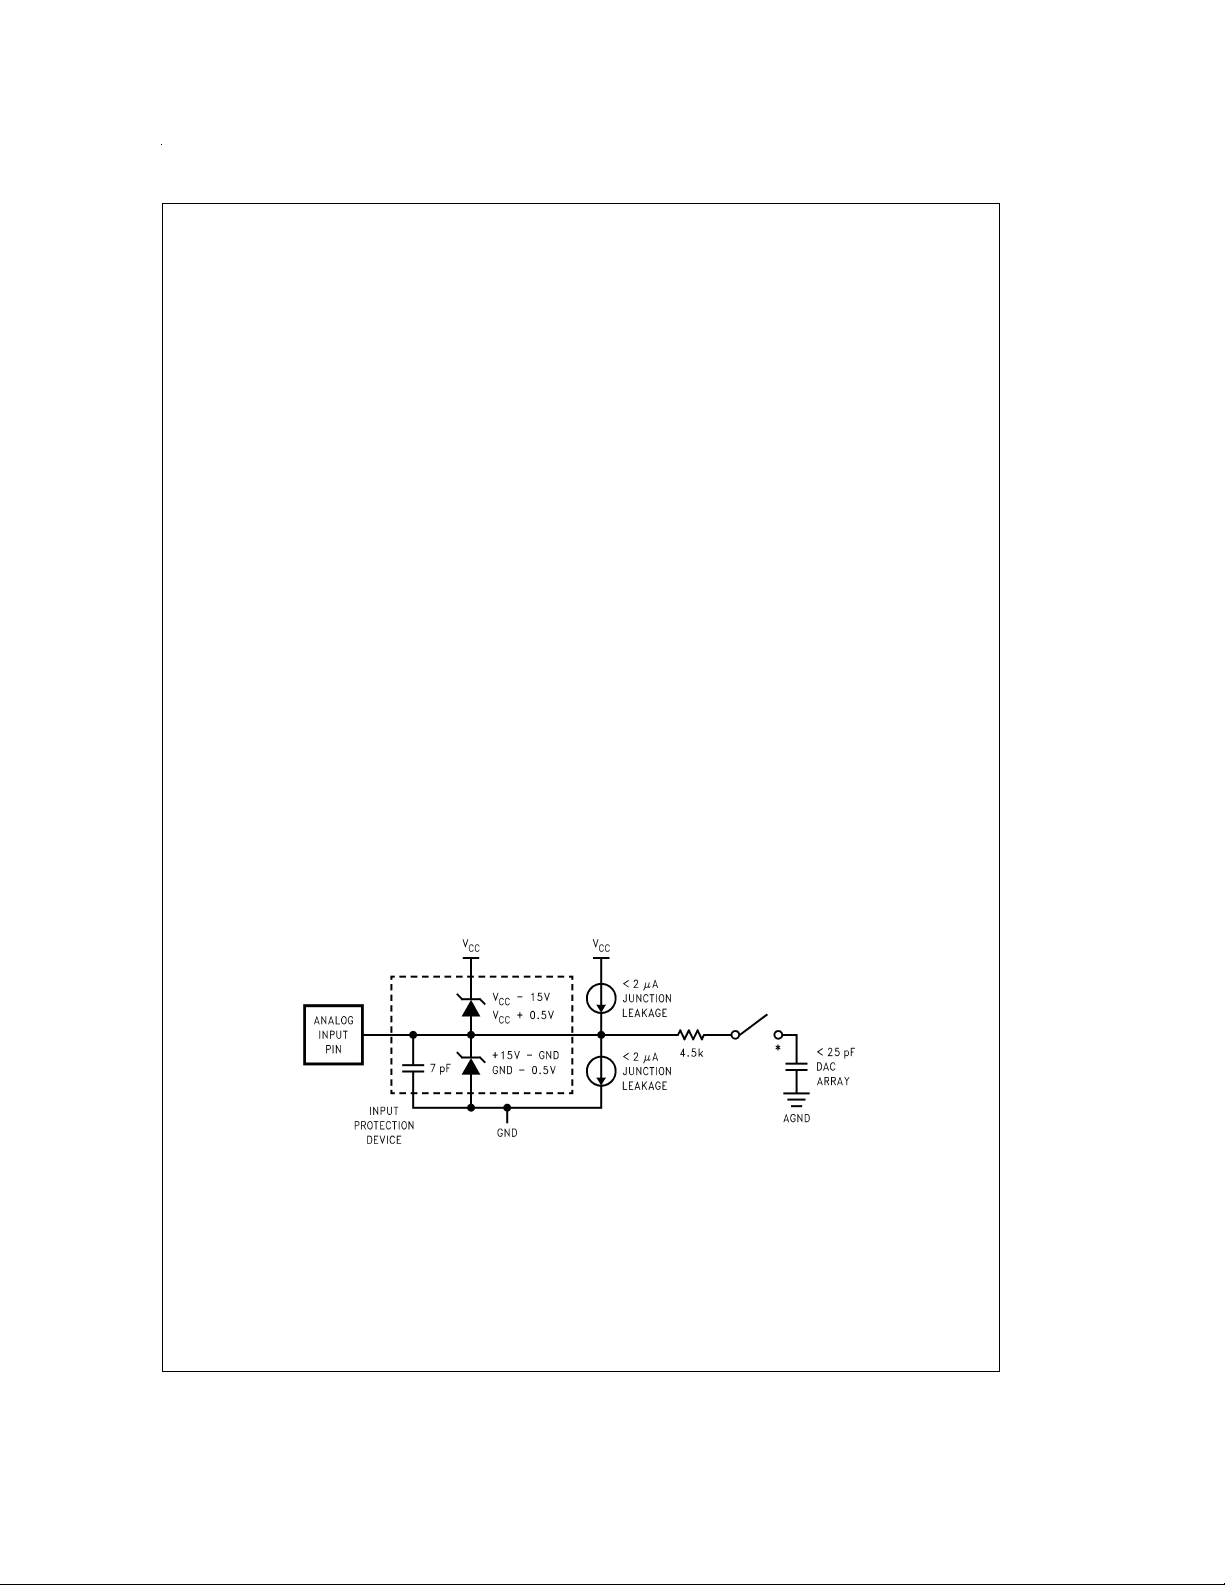
A/D Converter (Continued)
on for seven clock cycles. If the A/D is in single conversion
mode, the conversion complete signal from the A/D will generate a power down for the A/D converter and will clear the
ADBSY bit in the ENAD register at the next instruction cycle
boundary. If the A/D is in continuous mode, the conversion
complete signal will restart the conversion sequence by deselecting the A/D for one converter clock cycle before starting the next sample. The A/D 8-bit result is immediately
loaded into the A/D result register (ADRSLT) upon completion. Internal logic prevents transient data (resulting from the
A/D writing a new result over an old one) being read from
ADRSLT.
Inadvertent changes to the ENAD register during conversion
are prevented by the control logic of the A/D. Any attempt to
write any bit of the ENAD Register except ADBSY, while
ADBSY is a one, is ignored. ADBSY must be cleared either
by completion of anA/D conversion or by the user before the
prescaler, conversion mode or channel select values can be
changed.After stopping the current conversion, the user can
load different values for the prescaler, conversion mode or
channel select and start a new conversion in one instruction.
It is important for the user to realize that, when used in differential mode, only the positive input to the A/D converter is
sampled and held. The negative input is constantly connected and should be held stable for the duration of the conversion. Failure to maintain a stable negative input will result
in incorrect conversion.
PRESCALER
The A/D Converter (A/D) contains a prescaler option that allows four different clock selections. The A/D clock frequency
is equal to CKI divided by the prescaler value. Note that the
prescaler value must be chosen such that the A/D clock falls
within the specified range. The maximum A/D frequency is
1.67 MHz. This equates to a 600 ns A/D clock cycle.
The A/D converter takes 17 A/D clock cycles to complete a
conversion. Thus the minimum A/D conversion time for the
device is 10.2 µs when a prescaler of 6 has been selected.
The 17 A/D clock cycles needed for conversion consist of 1
cycle at the beginning for reset, 7 cycles for sampling, 8
cycles for converting, and 1 cycle for loading the result into
theA/D result register (ADRSLT).This A/D result register is a
read-only register. The user cannot write into ADRSLT.
TheADBSY flag provides an A/D clock inhibit function,which
saves power by powering down the A/D when it is not in use.
Note: The A/D converter is also powered down when the device is in either
the HALTor IDLE modes. If the A/D is running when the device enters
the HALT or IDLE modes, the A/D powers down and then restarts the
conversion with a corrupted sampled voltage (and thus an invalid result) when the device comes out of the HALT or IDLE modes.
Analog Input and Source Resistance Considerations
Figure 43
shows the A/D pin model in single ended mode.
The differential mode has a similarA/D pin model. The leads
to the analog inputs should be kept as short as possible.
Both noise and digital clock coupling to an A/D input can
cause conversion errors. The clock lead should be kept
away from the analog input line to reduce coupling. The A/D
channel input pins do not have any internal output driver circuitry connected to them because this circuitry would load
the analog input signals due to output buffer leakagecurrent.
Source impedances greater than 3 kΩ on the analog input
lines will adversely affect the internal RC charging time during input sampling.As shown in
Figure 43
, the analog switch
to the DAC array is closed only during the 7 A/D cycle
sample time. Large source impedances on the analog inputs
may result in the DAC array not being charged to the correct
voltage levels, causing scale errors.
If large source resistance is necessary, the recommended
solution is to slow down the A/D clock speed in proportion to
the source resistance. The A/D converter may be operated
at the maximum speed for R
than 3 kΩ, A/D clock speed needs to be reduced. For example, with R
at half the maximum speed. A/D converter clock speed may
=
6kΩ, the A/D converter may be operated
S
less than 3 kΩ. For RSgreater
S
be slowed down by either increasing the A/D prescaler
divide-by or decreasing the CKI clock frquency. The A/D
minimum clock speed is 100 kHz.
*
The analog switch is closed only during the sample time.
FIGURE 43. A/D Pin Model (Single Ended Mode)
DS012837-18
www.national.com55
Page 56

USART
The device contains a full-duplex software programmable
USART. The USART
register, a receiver shift register and seven addressable registers, as follows: a transmit buffer register (TBUF), a receiver buffer register (RBUF), a USART control and status
register (ENU), a USART receive control and status register
(ENUR), a USART interrupt and clock source register
(ENUI), a prescaler select register (PSR) and baud (BAUD)
register.The ENU register contains flags for transmit and receive functions; this register also determines the length of
the data frame (7, 8 or 9 bits), the value of the ninth bit in
transmission, and parity selection bits. The ENUR register
flags framing, data overrun and parity errors while the USART is receiving.
Figure 44
consists of a transmit shift
Other functions of the ENUR register include saving the
ninth bit received in the data frame, enabling or disabling the
USART’s attention mode of operation and providing additional receiver/transmitter status information via RCVG and
XMTG bits. The determination of an internal or external clock
source is done by the ENUI register, as well as selecting the
number of stop bits and enabling or disabling transmit and
receive interrupts. A control flag in this register can also select the USART mode of operation: asynchronous or
synchronous.
FIGURE 44. USART Block Diagram
www.national.com 56
DS012837-48
Page 57
USART (Continued)
USART CONTROL AND STATUS REGISTERS
The operation of the USART is programmed through three
registers: ENU, ENUR and ENUI.
DESCRIPTION OF USART REGISTER BITS
ENU-USART Control and Status Register (Address at
0BA)
PEN PSEL1 XBIT9/ CHL1 CHL0 ERR RBFL TBMT
PSEL0
Bit 7 Bit 0
PEN: This bit enables/disables Parity (7- and 8-bit modes
only). Read/Write, cleared on reset.
PEN = 0 Parity disabled.
PEN = 1 Parity enabled.
PSEL1, PSEL0: Parity select bits. Read/Write, cleared on
reset.
PSEL1 = 0, PSEL0 = 0 Odd Parity (if Parity enabled)
PSEL1 = 0, PSEL0 = 1 Even Parity (if Parity enabled)
PSEL1 = 1, PSEL0 = 0 Mark(1) (if Parity enabled)
PSEL1 = 1, PSEL0 = 1 Space(0) (if Parity enabled)
XBIT9/PSEL0: Programs the ninth bit for transmission when
the USART is operating with nine data bits per frame. For
seven or eight data bits per frame, this bit in conjunction with
PSEL1 selects parity. Read/Write, cleared on reset.
CHL1, CHL0: These bits select the character frame format.
Parity is not included and is generated/verified by hardware.
Read/Write, cleared on reset.
CHL1 = 0, CHL0 = 0 The frame contains eight data bits.
CHL1 = 0, CHL0 = 1 The frame contains seven data
bits.
CHL1 = 1, CHL0 = 0 The frame contains nine data bits.
CHL1 = 1, CHL0 = 1 Loopback Mode selected. Trans-
mitter output internally looped back
to receiver input. Nine bit framing
format is used.
ERR: This bit is a global USART error flag which gets set if
any or a combination of the errors (DOE, FE, PE) occur.
Read only; it cannot be written by software, cleared on reset.
RBFL: This bit is set when the USART has received a complete character and has copied it into the RBUF register.It is
automatically reset when software reads the character from
RBUF. Read only; it cannot be written by software, cleared
on reset.
TBMT: This bit is set when the USART transfers a byte of
data from the TBUF register into the TSFT register for transmission. It is automatically reset when software writes into
the TBUF register. Read only, bit is set to “one” on reset; it
cannot be written by software.
ENUR-USART Receive Control and Status Register
(Address at 0BB)
DOE FE PE Reserved RBIT9 ATTN XMTG RCVG
Bit 7 Bit 0
Note 33: Bit is reserved for future use. User must set to zero.
DOE: Flags a Data Overrun Error. Read only, cleared on
read, cleared on reset.
DOE = 0 Indicates no Data Overrun Error has been de-
tected since the last time the ENUR register
was read.
DOE = 1 Indicates the occurrence of a Data Overrun Er-
ror.
FE: Flags a Framing Error. Read only, cleared on read,
cleared on reset.
FE = 0 Indicates no Framing Error has been detected
since the last time the ENUR register was read.
FE = 1 Indicates the occurrence of a Framing Error.
PE: Flags a Parity Error. Read only, cleared on read, cleared
on reset.
PE = 0 Indicates no Parity Error has been detected since
the last time the ENUR register was read.
PE = 1 Indicates the occurrence of a Parity Error.
SPARE:Reserved for future use. Read/Write, cleared on re-
set.
RBIT9: Contains the ninth data bit received when the US-
ART is operating with nine data bits per frame. Read only,
cleared on reset.
ATTN: ATTENTION Mode is enabled while this bit is set.
This bit is cleared automatically on receiving a character with
data bit nine set. Read/Write, cleared on reset.
XMTG: This bit is set to indicate that the USART is transmitting. It gets reset atthe end of the lastframe (end of last Stop
bit). Read only, cleared on reset.
RCVG: This bit is set high whenever a framing error occurs
and goes low when RDX goes high. Read only, cleared on
reset.
ENUI-USART Interrupt and Clock Source Register
(Address at 0BC)
STP2 STP78 ETDX SSEL XRCLK XTCLK ERI ETI
Bit 7 Bit 0
STP2: This bit programs the number of Stop bits to be transmitted. Read/Write, cleared on reset.
STP2 = 0 One Stop bit transmitted.
STP2 = 1 Two Stop bits transmitted.
STP78: This bit is set to program the last Stop bit to be 7/8th
of a bit in length. Read/Write, cleared on reset.
ETDX: TDX (USART Transmit Pin) is the alternate function
assigned to Port L pin L2; it is selected by setting ETDX bit.
To simulate line break generation, software should reset
ETDX bit and output logic zero to TDX pin through Port L
data and configuration registers. Read/Write, cleared on reset.
SSEL: USART mode select. Read/Write, cleared on reset.
SSEL = 0 Asynchronous Mode.
SSEL = 1 Synchronous Mode.
XRCLK: This bit selects the clock source for the receiver
section. Read/Write, cleared on reset.
XRCLK = 0 The clock source is selected through the
PSR and BAUD registers.
XRCLK = 1 Signal on CKX (L1) pin is used as the clock.
XTCLK: This bit selects the clock source for the transmitter
section. Read/Write, cleared on reset.
XTCLK = 0 The clock source is selected through the
PSR and BAUD registers.
XTCLK = 1 Signal on CKX (L1) pin is used as the clock.
ERI: This bit enables/disables interrupt from the receiver
section. Read/Write, cleared on reset.
www.national.com57
Page 58
USART (Continued)
ERI = 0 Interrupt from the receiver is disabled.
ERI = 1 Interrupt from the receiver is enabled.
ETI: This bit enables/disables interrupt from the transmitter
section. Read/Write, cleared on reset.
ETI = 0 Interrupt from the transmitter is disabled.
ETI = 1 Interrupt from the transmitter is enabled.
Associated I/O Pins
Data is transmitted on the TDX pin and received on the RDX
pin. TDX is the alternate function assigned to Port L pin L2;
it is selected by setting ETDX (in the ENUI register) to one.
RDX is an inherent function of Port L pin L3, requiring no
setup.
The baud rate clock for the USART can be generated onchip, or can be taken from an external source. Port L pin L1
(CKX) is the external clock I/O pin. The CKX pin can be either an input or an output, as determined by Port L Configuration and Data registers (Bit 1). As an input, it accepts a
clock signal which may be selected to drive the transmitter
and/or receiver. As an output, it presents the internal Baud
Rate Generator output.
USART Operation
The USART has two modes of operation; asynchronous
mode and synchronous mode.
ASYNCHRONOUS MODE
This mode is selected by resetting the SSEL (in the ENUI
register) bit to zero. The input frequency to the USART is 16
times the baud rate.
The TSFT and TBUF registers double-buffer data for transmission. While TSFT is shifting out the current character on
the TDX pin, the TBUF register may be loaded by software
with the next byte to be transmitted. When TSFT finishes
transmitting the current character the contents of TBUF are
transferred to the TSFT register and the Transmit Buffer
Empty Flag (TBMT in the ENU register) is set. The TBMT
flag is automatically reset by the USART when software
loads a new character into the TBUF register. There is also
the XMTG bit which is set to indicate that the USART is
transmitting. This bit gets reset at the end of the last frame
(end of last Stop bit). TBUF is a read/write register.
The RSFT and RBUF registers double-buffer data being received. The USART receiver continually monitors the signal
on the RDX pin for a low level to detect the beginning of a
Start bit. Upon sensing this low level, it waits for half a bit
time and samples again. If the RDX pin is still low, the receiver considers this to bea valid Start bit, andthe remaining
bits in the character frame areeach sampled a single time, at
the mid-bit position. Serial data input on the RDX pin is
shifted into the RSFT register. Upon receiving the complete
character, the contents of the RSFT register are copied into
the RBUF register and the Received Buffer Full Flag (RBFL)
is set. RBFL is automatically reset when software reads the
character from the RBUF register. RBUF is a read only register. There is also the RCVG bit which is set high when a
framing error occurs and goes low once RDX goes high.
TBMT, XMTG, RBFL and RCVG are read only bits.
SYNCHRONOUS MODE
In this mode data is transferred synchronously with the
clock. Data is transmitted on the rising edge and received on
the falling edge of the synchronous clock.
This mode is selected by setting SSEL bit in the ENUI register. The input frequency to the USART is the same as the
baud rate.
When an external clock input isselected at the CKX pin, data
transmit and receive are performed synchronously with this
clock through TDX/RDX pins.
If data transmit and receive are selected with the CKX pin as
clock output, the device generates the synchronous clock
output at the CKX pin. The internal baud rate generator is
used to produce the synchronous clock. Data transmit and
receive are performed synchronously with this clock.
FRAMING FORMATS
The USART supports several serial framing formats (
45
) . The format is selected using control bits in the ENU,
ENUR and ENUI registers.
The first format (1, 1a, 1b, 1c) for data transmission (CHL0 =
1, CHL1 = 0) consists of Start bit, seven Data bits (excluding
parity) and 7/8, one or two Stop bits. In applications using
parity, the parity bit is generated and verified by hardware.
The second format (CHL0 = 0, CHL1 = 0) consists of one
Start bit, eight Data bits (excluding parity) and 7/8, one or
two Stop bits. Parity bit is generated and verified by hardware.
The third format for transmission (CHL0 = 0, CHL1 = 1) consists of one Start bit, nine Data bits and 7/8, one or two Stop
bits. This format also supports the USART “ATTENTION”
feature. When operating in this format, all eight bits of TBUF
and RBUF are used for data. The ninth data bitis transmitted
and received using two bits in the ENU and ENUR registers,
called XBIT9 and RBIT9. RBIT9 is a read only bit. Parity is
not generated or verified in this mode.
For any of the above framing formats, the last Stop bit can
be programmed to be 7/8th of a bit in length. If two Stop bits
are selected and the 7/8th bit is set (selected), the second
Stop bit will be 7/8th of a bit in length.
The parity is enabled/disabled by PEN bit located in the ENU
register. Parity is selected for 7-bit and 8-bit modes only. If
parity is enabled (PEN = 1), the parity selection is then performed by PSEL0 and PSEL1 bits located in the ENU
register.
Figure
www.national.com 58
Page 59
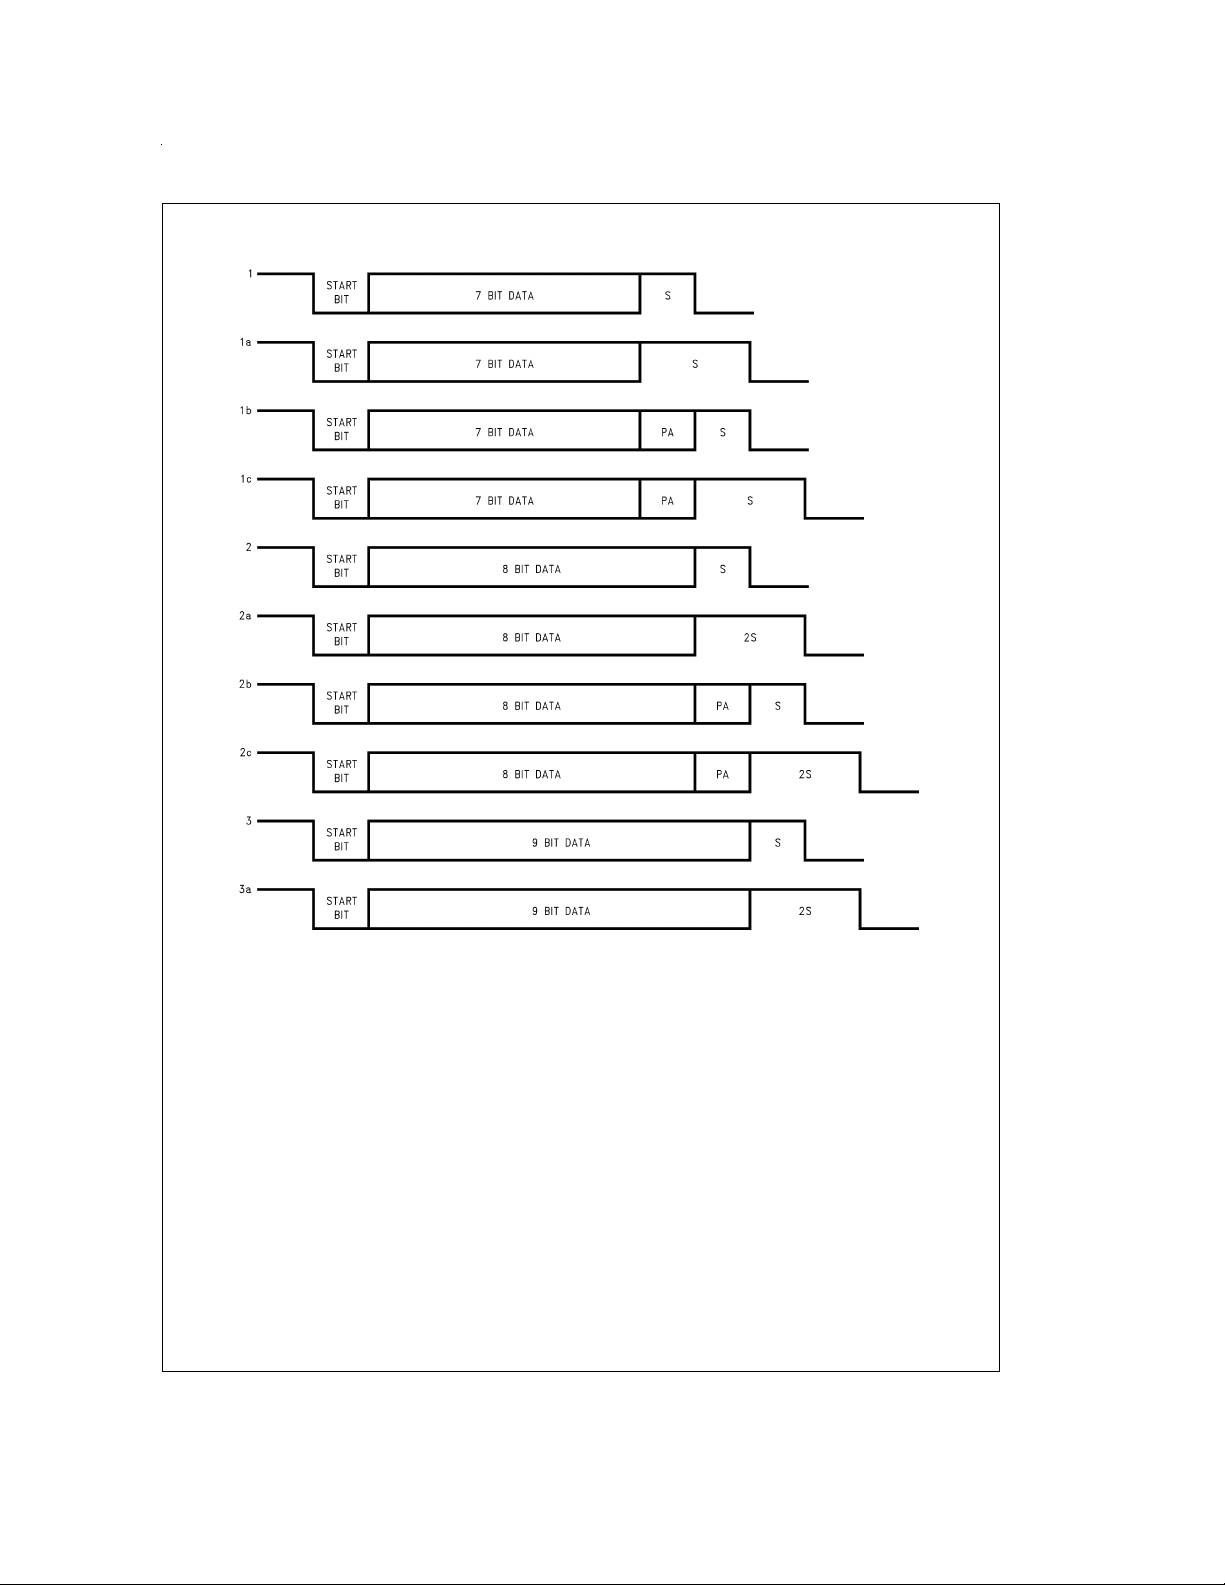
USART Operation (Continued)
FIGURE 45. Framing Formats
Note that the XBIT9/PSEL0 bit located in the ENU register
serves two mutually exclusive functions. This bit programs
the ninth bit for transmission when the USART is operating
with nine data bits per frame. There is no parity selection in
this framing format. For other framing formats XBIT9 is not
needed and the bit is PSEL0 used in conjunction with PSEL1
to select parity.
The frame formats for the receiver differ form the transmitter
in the number to Stop bits required. The receiver only requires one Stop bit ina frame, regardless of the setting ofthe
Stop bit selection bits in the control register. Note that an implicit assumption is made for full duplex USART operatioin
that the framing formats are the same for the transmitter and
receiver.
USART INTERRUPTS
The USART is capable of generating interrupts. Interrupts
are generated on Receive Buffer Full and Transmit Buffer
Empty. Both interrupts have individual interrupt vectors. Two
bytes of program memory space are reserved for each interrupt vector. The two vectors are located at addresses 0xEC
to 0xEF Hex in the program memory space. The interrupts
DS012837-49
can be individually enabled or disabled using Enable Transmit Interrupt (ETI) and Enable Receive Interrupt (ERI) bits in
the ENUI register.
The interrupt from the Transmitter is set pending, and remains pending, as long as both the TBMT and ETI bits are
set. To remove this interrupt, software must either clear the
ETI bit or write to the TBUF register (thus clearing the TBMT
bit).
The interrupt from the receiver is set pending, and remains
pending, as long as both the RBFL and ERI bits are set. To
remove this interrupt, software must either clear the ERI bit
or read from the RBUF register (thus clearing the RBFL bit).
Baud Clock Generation
The clock inputs to the transmitter and receiver sections of
the USART can be individually selected to come either from
an external source at the CKX pin (port L, pin L1) or from a
source selected in the PSR and BAUD registers. Internally,
the basic baud clock is created from the oscillator frequency
through a two-stage divider chain consisting of a 1–16 (increments of 0.5) prescaler and an 11-bit binary counter.(
ure 46
) The divide factors are specified through two read/
Fig-
www.national.com59
Page 60
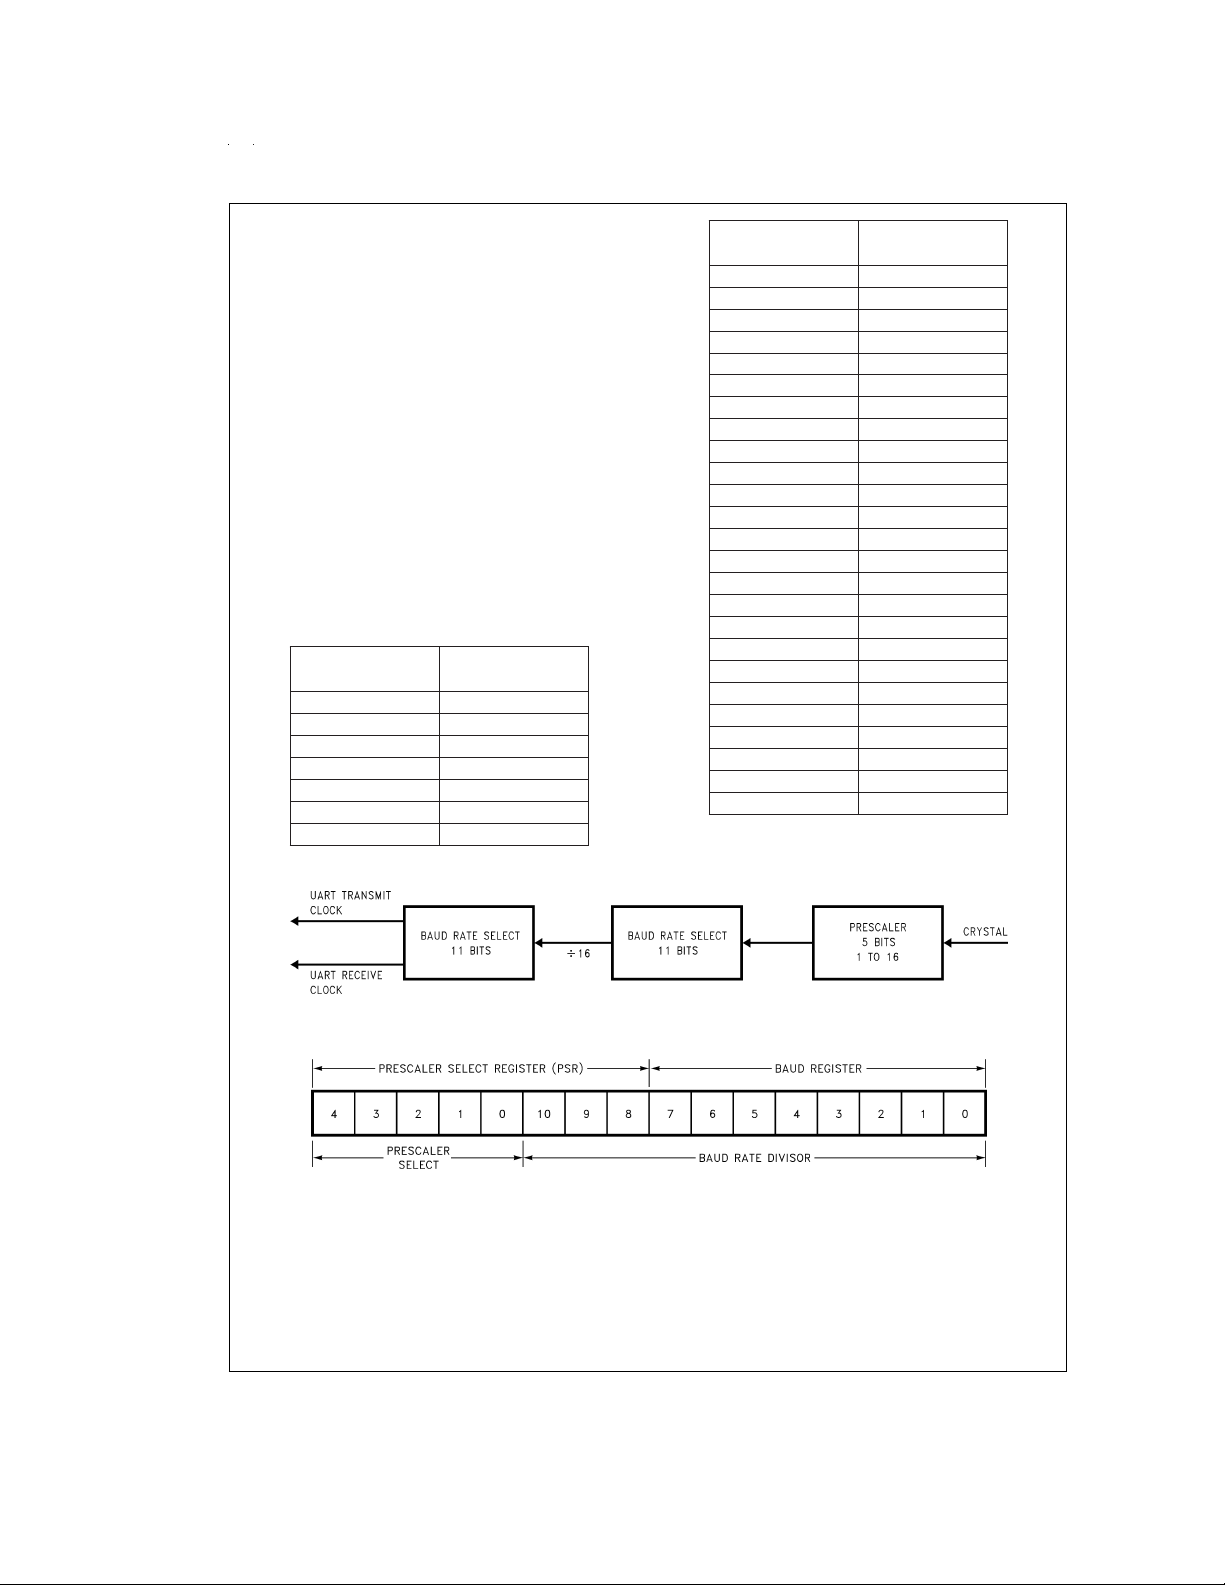
Baud Clock Generation (Continued)
write registers shown in
Rate Divisor spills over into the Prescaler Select Register
(PSR). PSR is cleared upon reset.
As shown in
Table15
NO CLOCK. NO CLOCK condition is the USART power
down mode where the USART clock is turned off for power
saving purpose. The user must also turn the USART clock
off when a different baud rate is chosen.
The correspondences between the 5-bit Prescaler Select
and Prescaler factors are shown in
many ways to calculate the two divisor factors, but one particularly effective method would be to achieve a 1.8432 MHz
frequency coming out of the first stage. The 1.8432 MHz
prescaler output is then used to drive the software programmable baud rate counter to create a x16 clock for the following baud rates: 110,134.5, 150, 300, 600, 1200, 1800, 2400,
3600, 4800, 7200, 9600, 19200 and 38400 (
baud rates may be created by using appropriate divisors.
The x16 clock isthen divided by 16 to provide the rate for the
serial shift registers of the transmitter and receiver.
Prescaler Prescaler
Select Factor
00000 NO CLOCK
00001 1
00010 1.5
00011 2
00100 2.5
00101 3
00110 3.5
Figure 47
. Note that the 11-bit Baud
, a Prescaler Factor of0 corresponds to
Table 15
Table16
TABLE 15. Prescaler Factors
. There are
). Other
Prescaler Prescaler
Select Factor
00111 4
01000 4.5
01001 5
01010 5.5
01011 6
01100 6.5
01101 7
01110 7.5
01111 8
10000 8.5
10001 9
10010 9.5
10011 10
10100 10.5
10101 11
10110 11.5
10111 12
11000 12.5
11001 13
11010 13.5
11011 14
11100 14.5
11101 15
11110 15.5
11111 16
FIGURE 46. USART BAUD Clock Generation
FIGURE 47. USART BAUD Clock Divisor Registers
www.national.com 60
DS012837-50
DS012837-51
Page 61
Baud Clock Generation (Continued)
TABLE 16. Baud Rate Divisors
(1.8432 MHz Prescaler Output)
Baud Baud Rate
Rate Divisor −1 (N-1)
110 (110.03) 1046
134.5 (134.58) 855
150 767
300 383
600 191
1200 95
1800 63
2400 47
3600 31
4800 23
7200 15
9600 11
19200 5
Note: The entries in
As an example, considering the Asynchronous Mode and a
CKI clock of 4.608 MHz, the prescaler factor selected is:
4.608/1.8432 = 2.5
The 2.5 entry is available in
caler output is then used with proper Baud Rate Divisor
(
Table 1
19200 e.g., the entry in
N−1=5(N−1isthevalue from
N=6(NistheBaud Rate Divisor)
Baud Rate = 1.8432 MHz/(16 x 6) = 19200
The divide by 16 is performed because in the asynchronous
mode, the input frequency to the USART is 16 times the
baud rate. The equation to calculate baud rates is given below.
The actual Baud Rate may be found from:
BR = Fc/(16XNXP)
Where:
BR is the Baud Rate
Fc is the CKI frequency
N is the Baud Rate Divisior (
P is the Prescaler Divide Factor selected by the value in the
Prescaler Select Register (
Note: In the Synchronous Mode, the divisor 16 is replaced by two.
Example:
Asynchronous Mode:
Crystal Frequency=5MHz
Desired baud rate = 9600
Using the above equationNXPcanbecalculated first.
NxP=(5X10
Now 32.552 is divided by each Prescaler Factor (
obtain a value closet to an integer. This factor happens to be
6.5 (P = 6.5).
N = 32.552/6.5 = 5.008 (N = 5)
The programmed value (from
Using the above values calculated for N and P:
38400 2
Table 16
the asynchronous mode the baud rate could be as high as 625k.
) to obtain different baud rates. For a baud rate of
assume a prescaler output of 1.8432 MHz. In
Table15
. The 1.8432 MHz pres-
Table 16
is 5.
Table 16
Table 16
).
Table 15
)
6
)/(16 x 9600) = 32.552
)
Table2
Table 10
) should be 4 (N −1).
)to
BR=(5x10
%
error = (9615.385 − 9600)/9600
6
)/(16x5x6.5) = 9615.384
*
100 = 0.16
Effect of HALT/IDLE
The USART logic is reinitialized when either the HALT or
IDLE modes are entered. This reinitialization sets the TBMT
flag and resets all read only bits in the USART control and
status registers. Read/Write bits remain unchanged. The
Transmit Buffer (TBUF) is not affected, but the Transmit Shift
register (TSFT) bits are set to one. The receiver registers
RBUF and RSFT are not affected.
The device will exit from the HALT/IDLE modes when the
Start bit of a character is detected at the RDX (L3) pin. This
feature is obtained by using the Multi-Input Wakeup scheme
provided on the device.
Before entering the HALT or IDLE modes the user program
must select the Wakeup source to be on the RXD pin. This
selection is done by setting bit 3 of WKEN (Wakeup Enable)
register.The Wakeup trigger condition is then selected to be
high to low transition. This is done via the WKEDG register.
(Bit 3 is one.)
If the device is halted and crystal oscillator is used, the
Wakeup signal will not start the chip running immediately because of the finite start up time requirement of the crystal oscillator.The idle timer (T0) generates a fixed (256 t
ensure that the oscillator has indeed stabilized before allowing the device to execute code. The user has to consider this
delay when data transfer is expected immediately after exiting the HALT mode.
) delay to
c
Diagnostic
Bits CHL0 and CHL1 in the ENU register provide a loopback
feature for diagnostic testing of the USART. When these bits
are set to one, the following occur: The receiver input pin
(RDX) is internally connected to the transmitter output pin
(TDX); the output of the Transmitter Shift Register is “looped
back” into the Receive Shift Register input. In this mode,
data that is transmitted is immediately received. This feature
allows the processor to verify the transmit and receive data
paths of the USART.
Note that the framing format for this mode is the nine bit format; one Start bit, nine data bits, and 7/8, one or two Stop
bits. Parity is not generated or verified in this mode.
Attention Mode
The USART Receiver section supports an alternate mode of
operation, referred to as ATTENTION Mode. This mode of
operation is selected by the ATTN bit in the ENUR register.
The data format for transmission must also be selected as
having nine Data bits and either 7/8, one or two Stop bits.
The ATTENTION mode of operation is intended for use in
networking the device with other processors, Typically in
such environments the messages consists of device addresses, indicating which of several destinations should receive them, and the actual data. This Mode supports a
scheme in which addresses are flagged by having the ninth
bit of the data field set to a 1. If the ninth bit is reset to a zero
the byte is a Data byte.
While in ATTENTION mode, the USART monitors the communication flow, but ignores all characters until an address
character is received. Upon receiving an address character,
the USART signals that the character is ready by setting the
RBFL flag, which in turn interrupts the processor if USART
Receiver interrupts are enabled. The ATTNbit isalso cleared
www.national.com61
Page 62
Attention Mode (Continued)
automatically at this point, so that data characters as well as
address characters are recognized. Software examines the
contents of the RBUF and responds by deciding either to accept the subsequent data stream (by leaving the ATTN bit reset) or to wait until the next address character is seen (by
setting the ATTN bit again).
Operation of the USARTTransmitter is not affected by selection of this Mode. The value of the ninth bit to be transmitted
is programmed by setting XBIT9 appropriately. The value of
the ninth bit received is obtained by reading RBIT9. Since
this bit is located in ENUR register where the error flags reside, a bit operation on it will reset the error flags.
WATCHDOG
The device contains a WATCHDOG and clock monitor. The
WATCHDOG is designed to detect the user program getting
stuck in infinite loops resulting in loss of program control or
“runaway” programs. The Clock Monitor is used to detect the
absence of a clock or a very slow clock below a specified
rate on the CKI pin.
The WATCHDOG consists of two independent logic blocks:
WD UPPER and WD LOWER. WD UPPER establishes the
upper limit on the service window and WD LOWER defines
the lower limit of the service window.
Servicing the WATCHDOG consists of writing a specific
value to a WATCHDOG Service Register named WDSVR
which is memory mapped in the RAM. This value is composed of three fields, consisting of a 2-bit Window Select, a
5-bit Key Data field, and the 1-bit Clock Monitor Select field.
Table 17
shows the WDSVR register.
TABLE 17. WATCHDOG Service Register (WDSVR)
Window Key Data Clock
Select Monitor
X X01100 Y
Bit 7 Bit 0
The lower limit of the service window is fixed at 2048 instruction cycles. Bits 7 and 6 of the WDSVR register allow the
user to pick an upper limit of the service window.
Table18
shows the four possible combinations of lower and
upper limits for the WATCHDOG service window. This flexibility in choosing the WATCHDOG service window prevents
any undue burden on the user software.
TABLE 18. WATCHDOG Service Window Select
WDSVR WDSVR Clock Service Window
Bit 7 Bit 6 Monitor (Lower-Upper Limits)
0 0 x 2048–8k t
0 1 x 2048–16k t
1 0 x 2048–32k t
1 1 x 2048–64k t
x x 0 Clock Monitor Disabled
x x 1 Clock Monitor Enabled
Bits 5, 4, 3, 2 and 1 of the WDSVR register represent the
5-bit Key Data field. The key data is fixed at 01100. Bit 0 of
the WDSVR Register is the Clock Monitor Select bit.
C
C
C
C
Cycles
Cycles
Cycles
Cycles
Clock Monitor
The Clock Monitor aboard the device can be selected or deselected under program control. The Clock Monitor is guaranteed not to reject the clock if the instruction cycle clock
(1/t
) is greater or equal to10 kHz.This equatesto aclock in-
c
put rate on CKI of greater or equal to 100 kHz.
WATCHDOG Operation
The WATCHDOG and Clock Monitor are disabled during reset. The device comes out of reset with the WATCHDOG
armed, the WATCHDOG Window Select (bits 6, 7 of the
WDSVR Register) set, and the Clock Monitor bit (bit 0 of the
WDSVR Register) enabled. Thus, a Clock Monitor error will
occur after coming out of reset, if the instruction cycle clock
frequency has not reached a minimum specified value, including the case where the oscillator fails to start.
The WDSVR register can be written to only once after reset
and the key data (bits 5 through 1 of the WDSVR Register)
must match to be a valid write.This write to the WDSVR register involves two irrevocable choices: (i) the selection of the
WATCHDOG service window (ii) enabling or disabling of the
Clock Monitor. Hence, the first write to WDSVR Register involves selecting or deselecting the Clock Monitor, select the
WATCHDOG service window and match the WATCHDOG
key data. Subsequent writes to the WDSVR register will
compare the value being written by the user to the WATCHDOG service window value and the key data (bits 7 through
1) in the WDSVR Register.
events that can occur.
The user must service the WATCHDOG at least once before
the upper limit of the service window expires. The WATCHDOG may not be serviced more than once in every lower
limit of the service window. The user may service the
WATCHDOG as many times as wished in thetime period between the lower and upper limits of the service window.The
first write to the WDSVR Register is also counted as a
WATCHDOG service.
The WATCHDOG has an output pin associated with it. This
is the WDOUT pin, on pin 1 of the Port G. WDOUT is active
low.The WDOUT pin is in the high impedance state in the inactive state. Upon triggering the WATCHDOG, the logic will
pull the WDOUT (G1) pin low for an additonal 16 t
cycle after the signal level on WDOUT pin goes below the
lower Schmitt trigger threshold. After this delay, the device
will stop forcing the WDOUT output low.
The WATCHDOG service window will restart when the WDOUT pin goes high. It is recommended that the user tie the
WDOUT pin back to V
WDOUT high.
AWATCHDOG service while the WDOUTsignal is active will
be ignored. The state of the WDOUT pin is not guaranteed
on reset, but if the powers up low then the WATCHDOG will
time out and WDOUT will enter high impedance state.
The Clock Monitor forces the G1 pin low upon detecting a
clock frequency error. The Clock Monitor error will continue
until the clock frequency has reached the minimum specified
value, after which the G1 output will enter the high impedance TRI-STATE mode following 16 t
The Clock Monitor generates a continual Clock Monitor error
if the oscillator fails to start, or fails to reach the minimum
specified frequency. The specification for the Clock Monitor
is as follows:
>
1/t
10 kHz— No clock rejection.
c
<
10 Hz— Guaranteed clock rejection.
1/t
c
Table19
shows the sequence of
through a resistor in order to pull
CC
–32 tcclock cycles.
c
–32t
c
c
www.national.com 62
Page 63
WATCHDOG Operation (Continued)
WATCHDOG AND CLOCK MONITOR SUMMARY
The following salient points regarding the COP888 WATCHDOG and CLOCK MONITOR should be noted:
Both the WATCHDOG and Clock Monitor detector cir-
•
cuits are inhibited during RESET.
Following RESET, the WATCHDOG and CLOCK MONI-
•
TOR are both enabled, with the WATCHDOG having the
maximum service window selected.
The WATCHDOG service window and Clock Monitor
•
enable/disable option can only be changed once, during
the initial WATCHDOG service following RESET.
The initial WATCHDOGservice must match the key data
•
value in the WATCHDOG Service register WDSVR in order to avoid a WATCHDOG error.
Subsequent WATCHDOG services must match all three
•
data fields in WDSVR in order to avoid WATCHDOG errors.
The correct key data value cannot be read from the
•
WATCHDOG Service register WDSVR. Any attempt to
read this key data value of 01100 from WDSVR will read
as key data value of all 0’s.
The WATCHDOG detector circuit is inhibited during both
•
the HALT and IDLE modes.
The Clock Monitor detector circuit is active during both
•
the HALT and IDLE modes. Consequently, the device inadvertently entering the HALTmode will be detected as a
Clock Monitor error (provided that the Clock Monitor enable option has been selected by the program).
With the single-pin R/C oscillator mask option selected
•
and the CLKDLY bit reset, the WATCHDOG service window will resume following HALT mode from where it left
off before entering the HALT mode.
TABLE 19. WATCHDOG Service Actions
Key Window Clock Action
Data Data Monitor
Match Match Match Valid Service: Restart Service Window
Don’t Care Mismatch Don’t Care Error: Generate WATCHDOG Output
Mismatch Don’t Care Don’t Care Error: Generate WATCHDOG Output
Don’t Care Don’t Care Mismatch Error: Generate WATCHDOG Output
With the crystal oscillator mask option selected, or with
•
the single-pin R/C oscillator mask option selected and the
CLKDLYbit set, the WATCHDOG service window will be
set to its selected value from WDSVR following HALT.
Consequently, the WATCHDOG should not be serviced
for at least 2048 instruction cycles following HALT, but
must be serviced within the selected window to avoid a
WATCHDOG error.
The IDLE timer T0 is not initialized with RESET.
•
The user can sync in to the IDLE counter cycle with an
•
IDLE counter (T0) interrupt or by monitoring the T0PND
flag. The T0PND flag is set whenever the thirteenth bit of
the IDLE counter toggles (every 4096 instruction cycles).
The user is responsible for resetting the T0PND flag.
A hardware WATCHDOG service occurs just as the de-
•
vice exits the IDLE mode. Consequently, the WATCHDOG should not be serviced for at least 2048 instruction
cycles following IDLE, but must be serviced within the selected window to avoid a WATCHDOG error.
Following RESET, the initial WATCHDOGservice (where
•
the service window and the CLOCK MONITOR enable/
disable must be selected) may be programmed anywhere within the maximum service window (65,536 instruction cycles) initialized by RESET. Note that this initial
WATCHDOG service may be programmed within the intitial 2048 instruction cycles without causing a WATCHDOG error.
www.national.com63
Page 64
Memory Map
All RAM, ports and registers (except A and PC) are mapped
into data memory address space.
Address Contents
0000 to 006F On-Chip RAM bytes (112
bytes)
0070 to 007F Unused RAM Address Space
(Reads as All Ones)
0080 PORTMD, Port M Data
Register
0081 PORTMC, Port M
Configuration Register
0082 PORTMP, Port M Input Pins
(Read Only)
0083 Reserved for Port M
0084 MMIWU Edge Select Register
(MWKEDG)
0085 MMIWU Enable Register
(MWKEN)
0086 MMIWU Pending Register
(MWKPND)
0087 Reserved for MMIWU
0088 PORTND, Port N Data
Register
0089 PORTNC, Port N
Configuration Register
008A PORTNP, Port N Input Pins
(Read Only)
008B PORTNX, Port N Alternate
Function Enable
008C to 008F Unused RAM Address Space
(Reads Undefined Data)
0090 PORTED, Port E Data
Register
0091 PORTEC, Port E
Configuration Register
0092 PORTEP, Port E Input Pins
(Read Only)
0093 Reserved for Port E
0094 PORTFD, Port F Data
Register
0095 PORTFC, Port F
Configuration Register
0096 PORTFP, Port F Input Pins
(Read Only)
0097 Reserved for Port F
0098 SPICNTL, SPI Control
Register
0099 SPISTAT, SPI Status Register
009A SPIRXD, SPI Current Receive
Data (Read Only)
009B SPITXD, SPI Transmit Data
009C to 009F Reserved
00A0 TXD1, Transmit 1 Data
00A1 TXD2, Transmit 2 Data
Address Contents
00A2 TDLC, Transmit Data Length
Code and Identifier Low
00A3 TID, Transmit Identifier High
00A4 RXD1, Receive Data 1
00A5 RXD2, Receive Data 2
00A6 RIDL, Receive Data Length
Code
00A7 RID, Receive Identify HIgh
00A8 CSCAL, CAN Prescaler
00A9 CTIM, Bus Timing Register
00AA CBUS, Bus Control Register
00AB TCNTL, Transmit/Receive
Control Register
00AC RTSTAT Receive/Transmit
Status Register
00AD TEC, Transmit Error Count
Register
00AE REC, Receive Error Count
Register
00AF PLATST, CAN Bit Stream
Processor Test Register
00B8 UART Transmit Buffer (TBUF)
00B9 UART Receive Buffer (RBUF)
00BA UART Control Status (ENU)
00BB UART Receive Control Status
(ENUR)
00BC UART Interrupt and Clock
(ENUI)
00BD UART Baud Register (BAUD)
00BE UART Prescaler Register
(PSR)
00BF Reserved for UART
00C0 Timer T2 Lower Byte
(TMR2LO)
00C1 Timer T2 Upper Byte
(TMR2HI)
00C2 Timer T2 Autoload Register
T2RA Lower Byte (T2RALO)
00C3 Timer T2 Autoload Register
T2RA Upper Byte (T2RAHI)
00C4 Timer T2 Autoload Register
T2RB Lower Byte (T2RBLO)
00C5 Timer T2 Autoload Register
T2RB Upper Byte (T2RBHI)
00C6 Timer T2 Control Register
(T2CNTRL)
00C7 WATCHDOG Service
Register (Reg:WDSVR)
00C8 LMIWU Edge Select Register
(LWKEDG)
00C9 LMIWU Enable Register
(LWKEN)
00CA LLMIWU Pending Register
(LWKPND)
www.national.com 64
Page 65
Memory Map (Continued)
Address Contents
00CB A/D Converter Control
00CC A/D Converter Result Register
00CD to
00CE
00CF IDLE Timer Control Register
00D0 PORTLD, Port L Data
00D1 PORTLC, Port L
00D2 PORTLP, Port L Input Pins
00D3 Reserved for Port L
00D4 PORTGD, Port G Data
00D5 PORTGC, Port G
00D6 PORTGP, Port G Input Pins
00D7 Port I Input Pins (Read Only)
00D8 Port CD, Port C Data Register
00D9 Port CC, Port C Configuration
00DA Port CP, Port C Input Pins
00DB Reserved for Port C
00DC Port D
00DD to
00DF
00E0 to
00E5
00E6 Timer T1 Autoload Register
00E7 Timer T1 Autoload Register
00E8 ICNTRL Register
00E9 MICROWIRE/PLUS Shift
00EA Timer T1 Lower Byte
00EB Timer T1 Upper Byte
00EC Timer T1 Autoload Register
00ED Timer T1 Autoload Register
00EE CNTRL, Control Register
00EF PSW, Processor Status Word
Register (Reg:ENAD)
(Reg:ADRSLT)
Reserved
(Reg:ITMR)
Register
Configuration Register
(Read Only)
Register
Configuration Register
(Read Only)
Register
(Read Only)
Reserved for Port D
Reserved for EE Control
Registers
T1RB Lower Byte (T1BRLO)
T1RB Upper Byte (T1BRHI)
Register (SOIR)
(TMR1LO)
(TMR1HI)
T1RA Lower Byte (T1RALO)
T1RA Upper Byte (T1RAHI)
Register
Address Contents
00F0 to
00FB
00FC X Register
00FD SP Register
00FE B Register
00FF S Register
0100 to 013F On-Chip RAM Bytes (64
Reading memory locations 0070H–007FH will
return all ones.
Reading unused memory locations 00xxH–00xxH
will return undefined data.
On-Chip RAM Mapped as
Registers
Bytes)
Addressing Modes
There are ten addressing modes, six for operand addressing
and four for transfer of control.
OPERAND ADDRESSING MODES
Register Indirect
This is the “normal” addressing mode. The operand is the
data memory addressed by the B pointer or X pointer.
Register Indirect (with auto post increment or
decrement of pointer)
This addressing mode is used with the LD and X instructions. The operand is the data memory addressed by the B
pointer or X pointer. This is a register indirect mode that automatically post increments or decrements the B or X register after executing the instruction.
Direct
The instruction contains an 8-bit address field that directly
points to the data memory for the operand.
Immediate
The instruction contains an 8-bit immediate field as the operand.
Short Immediate
This addressing mode is used with the Load B Immediate instruction. The instruction contains a 4-bit immediate field as
the operand.
Indirect
This addressing mode is used with the LAID instruction. The
contents of the accumulator are used as a partial address
(lower 8 bits of PC) for accessing a data operand from the
program memory.
TRANSFER OF CONTROL ADDRESSING MODES
Relative
This mode is used for the JP instruction, with the instruction
field being added to the program counter to get the new program location. JP has a range from −31 to +32 to allow a
1-byte relatie jump (JP + 1 is implemented by a NOP instruction). There are no “pages” when using JP,since all 15bits of
PC are used.
www.national.com65
Page 66
Addressing Modes (Continued)
Absolute
The mode is used with the JMP and JSR instructions, with
the instruction field of 12 bits replacing the lower 12 bits of
the program counter (PC). This allows jumping to any location in the current 4k program memory segment.
Absolute Long
This mode is used with the JMPL and JSRL instructions, with
the instruction field of 15 bits replacing the entire 15 bits of
the program counter (PC). This allows jumping to any location up to 32k in the program memory space.
Indirect
This mode is used with the JID instruction. The contents of
the accumulator are used as apartial address (lower 8 bits of
PC) for accessing a location in the program memory. The
contents of this program memory location serve as a partial
address (lower 8 bits of PC) for the jump to the next instruction.
Note: The VIS is a special case of the Indirect Transfer of Control addressing
mode, where the double byte vector associated with the interrupt is
transferred from adjacent addresses in the program memory into the
program counter (PC) in order to jump to the associated interrupt service routine.
Instruction Set
Register and Symbol Definition
Registers
A 8-Bit Accumulator Register
B 8-Bit Address Register
X 8-Bit Address Register
SP 8-Bit Stack Pointer Register
PC 15-Bit Program Counter Register
PU Upper 7 Bits of PC
PL Lower 8 Bits of PC
C 1 Bit of PSW Register for Carry
HC 1 Bit of PSW Register for Half Carry
GIE 1 Bit of PSW Register for Global Interrupt Enable
VU Interrupt Vector Upper Byte
VL Interrupt Vector Lower Byte
Symbols
[B] Memory Indirectly Addressed by B Register
[X] Memory Indirectly Addressed by X Register
MD Direct Addressed Memory
Mem Direct Addressed Memory or [B]
Meml Direct Addressed Memory or [B] or
Immediate Data
Imm 8-Bit Immediate Data
Reg Register Memory: Addresses F0 to FF
(Includes B, X and SP)
Bit Bit Number (0 to 7)
←
↔
Loaded with
Exchanged with
www.national.com 66
Page 67
Instruction Set (Continued)
INSTRUCTION SET
ADD A,Meml ADD A←A + Meml
ADC A,Meml ADD with Carry A←A+Meml+C,C←Carry,
HC←Half Carry,
SUBC A,Meml Subtract with Carry A←A−MemI+C,C←Carry,
HC←Half Carry
AND A,Meml Logical AND A←A and Meml
ANDSZ A,Imm Logical AND Immed., Skip if Zero Skip next if (A and Imm) = 0
OR A,Meml Logical OR A←A or Meml
XOR A,Meml Logical EXclusive OR A←A xor Meml
IFEQ MD,Imm IF EQual Compare MD and Imm, Do next if MD = Imm
IFEQ A,Meml IF EQual Compare A and Meml, Do next if A = Meml
IFNE A,Meml IF Not Equal Compare A and Meml, Do next if A
IFGT A,Meml IF Greater Than Compare A and Meml, Do next if A
IFBNE # IF B Not Equal Do next if lower 4 bits of B
DRSZ Reg Decrement Reg., Skip if Zero Reg←Reg − 1, Skip if Reg = 0
SBIT #,Mem Set BIT 1 to bit, Mem (bit=0to7immediate)
RBIT #,Mem Reset BIT 0 to bit, Mem
IFBIT #,Mem IF BIT If bit in A or Mem is true do next instruction
RPND Reset PeNDing Flag Reset Software Interrupt Pending Flag
X A,Mem EXchange A with Memory A
X A,[X] EXchange A with Memory [X] A
LD A,Meml LoaD A with Memory A←Meml
LD A,[X] LoaD A with Memory [X] A←[X]
LD B,Imm LoaD B with Immed. B←Imm
LD Mem,Imm LoaD Memory Immed. Mem←Imm
LD Reg,Imm LoaD Register Memory Immed. Reg←Imm
X A, [B] EXchange A with Memory [B] A
X A, [X] EXchange A with Memory [X] A
LD A, [B] LoaD A with Memory [B] A←[B], (B←B1)
LD A,[X] LoaD A with Memory [X] A←[X], (X←X1)
LD [B],Imm LoaD Memory [B] Immed. [B]←Imm, (B←B1)
CLR A CLeaR A A←0
INC A INCrement A A←A+1
DEC A DECrement A A←A−1
LAID Load A InDirect from ROM A←ROM (PU,A)
DCOR A Decimal CORrect A A←BCD correction of A (follows ADC, SUBC)
RRC A Rotate A Right thru C C→A7→…→A0→C
RLC A Rotate A Left thru C C←A7←…←A0←C
SWAP A SWAP nibbles of A A7…A4
SC Set C C←1, HC←1
RC Reset C C←0, HC←0
IFC IF C IF C is true, do next instruction
IFNC IF Not C If C is not true, do next instruction
POP A POP the stack into A SP←SP+1,A←[SP]
PUSH A PUSH A onto the stack [SP]←A, SP←SP−1
VIS Vector to Interrupt Service Routine PU←[VU], PL←[VL]
JMPL Addr. Jump absolute Long PC←ii (ii = 15 bits, 0 to 32k)
JMP Addr. Jump absolute PC9…0←i (i = 12 bits)
JP Disp. Jump relative short PC←PC+r(ris−31to+32, except 1)
↔
Mem
↔
[X]
↔
[B], (B←B1)
↔
[X], (X←X1)
↔
A3…A0
≠
Meml
>
Meml
≠
Imm
www.national.com67
Page 68

Instruction Set (Continued)
INSTRUCTION SET (Continued)
JSRL Addr. Jump SubRoutine Long [SP]←PL, [SP−1]←PU,SP−2, PC←ii
JSR Addr. Jump SubRoutine [SP]←PL, [SP−1]←PU,SP−2, PC9…0←i
JID Jump InDirect PL←ROM (PU,A)
RET RETurn from subroutine SP + 2, PL←[SP], PU←[SP−1]
RETSK RETurn and SKip SP + 2, PL←[SP],PU←[SP−1]
RETI RETurn from Interrupt SP + 2, PL←[SP],PU←[SP−1],GIE←1
INTR Generate an Interrupt [SP]←PL, [SP−1]←PU, SP−2, PC←0FF
NOP No OPeration PC←PC+1
www.national.com 68
Page 69
Instruction Set (Continued)
INSTRUCTION EXECUTION TIME
Most instructions are single byte (with immediate addressing
mode instructions taking two bytes).
Most single byte instructions take one cycle time to execute.
Skipped instructions require x number of cycles to be
skipped, where x equals the number of bytes in the skipped
instruction opcode.
See the BYTES and CYCLES per INSTRUCTION table for
details.
Bytes and Cycles per Instruction
The following table shows the number of bytes and cycles for
each instruction in the format of byte/cycle.
Arithmetic and Logic Instructions
[B] Direct Immed.
ADD 1/1 3/4 2/2
ADC 1/1 3/4 2/2
SUBC 1/1 3/4 2/2
AND 1/1 3/4 2/2
OR 1/1 3/4 2/2
XOR 1/1 3/4 2/2
IFEQ 1/1 3/4 2/2
IFGT 1/1 3/4 2/2
IFBNE 1/1
DRSZ 1/3
SBIT 1/1 3/4
RBIT 1/1 3/4
IFBIT 1/1 3/4
RPND 1/1
Instructions Using A and C
CLRA 1/1
INCA 1/1
DECA 1/1
LAID 1/3
DCORA 1/1
RRCA 1/1
RLCA 1/1
SWAPA 1/1
SC 1/1
RC 1/1
IFC 1/1
IFNC 1/1
PUSHA 1/3
POPA 1/3
ANDSZ 2/2
Transfer of Control Instructions
JMPL 3/4
JMP 2/3
JP 1/3
JSRL 3/5
JSR 2/5
JID 1/3
VIS 1/5
RET 1/5
RETSK 1/5
RETI 1/5
INTR 1/7
NOP 1/1
Memory Transfer Instructions
Register Register Indirect
Indirect Direct Immed. Auto Incr. and Decr.
[B] [X] [B+, B−] [X+, X−]
X A, (Note 34) 1/1 1/3 2/3 1/2 1/3
LD A, (Note 34) 1/1 1/3 2/3 2/2 1/2 1/3
LD B, Imm 1/1 (IF B
LD B, Imm 2/3 (IF B
LD Mem, Imm 2/2 3/3 2/2
LD Reg, Imm 2/3
IFEQ MD, Imm 3/3
Note 34: =>Memory location addressed by B or X or directly.
<
16)
>
15)
www.national.com69
Page 70
Upper Nibble
JP+17 INTR 0
JMP
x000–x0FF
x000–x0FF
IFBNE 0 JSR
LD
B,#0F
A, #i
ANDSZ
0,[B]
IFBIT
JP+18 JP+2 1
JMP
x100–x1FF
x100–x1FF
IFBNE 1 JSR
B,#0E
*LD
1,[B]
IFBIT
JP+19 JP+3 2
JP+20 JP+4 3
JMP
JMP
x200–x2FF
x200–x2FF
IFBNE 2 JSR
IFBNE 3 JSR
B,#0D
*LD
*LD
2,[B]
IFBIT
IFBIT
x300–x3FF
x300–x3FF
B,#0C
3,[B]
JP+21 JP+5 4
JMP
x400–x4FF
x400–x4FF
IFBNE 4 JSR
B,#0B
CLRA LD
4,[B]
IFBIT
JP+22 JP+6 5
JMP
x500–x5FF
x500–x5FF
IFBNE 5 JSR
B,#0A
SWAPA LD
5,[B]
IFBIT
JP+23 JP+7 6
JMP
x600–x6FF
x600–x6FF
IFBNE 6 JSR
B,#09
DCORA LD
6,[B]
IFBIT
JP+24 JP+8 7
JMP
IFBNE 7 JSR
PUSHA LD
IFBIT
x700–x7FF
x700–x7FF
B,#08
7,[B]
JP+25 JP+9 8
JMP
IFBNE 8 JSR
LD
RBIT
x800–x8FF
x800–x8FF
B,#07
0,[B]
0,[B]
Lower Nibble
JP+26 JP+10 9
JMP
IFBNE 9 JSR
LD
RBIT
x900–x9FF
x900–x9FF
B,#06
1,[B]
1,[B]
JP+27 JP+11 A
JMP
IFBNE 0A JSR
LD
RBIT
xA00–xAFF
xA00–xAFF
B,#05
2,[B]
2,[B]
JP+28 JP+12 B
JMP
IFBNE 0B JSR
LD
RBIT
xB00–xBFF
xB00–xBFF
B,#04
3,[B]
3,[B]
JP+29 JP+13 C
JMP
IFBNE 0C JSR
LD
RBIT
xC00–xCFF
xC00–xCFF
B,#03
4,[B]
4,[B]
JP+30 JP+14 D
JMP
IFBNE 0D JSR
LD
RBIT
xD00–xDFF
xD00–xDFF
B,#02
5,[B]
5,[B]
JP+31 JP+15 E
JMP
IFBNE 0E JSR
LD
RBIT
xE00–xEFF
xE00–xEFF
B,#01
6,[B]
6,[B]
JP+32 JP+16 F
JMP
IFBNE 0F JSR
LD
RBIT
xF00–xFFF
xF00–xFFF
B,#00
7,[B]
7,[B]
ADC
A,[B]
A,#i
RRCA RC ADC
0F0
F E D C BA9 876 5 4 3 2 10
Opcode Table
www.national.com 70
JP−15 JP−31 LD 0F0, #i DRSZ
A,[B]
SUBC
A, #i
* SC SUBC
0F1
JP−14 JP−30 LD 0F1, #i DRSZ
A,[B]
IFEQ
A,#i
IFEQ
X
A,[B+]
X
A,[X+]
0F2
JP−13 JP−29 LD 0F2, #i DRSZ
A,[B]
IFGT
A,#i
IFGT
X
A,[B−]
X
A,[X−]
0F3
JP−12 JP−28 LD 0F3, #i DRSZ
ADD
A,[B]
A,#i
VIS LAID ADD
0F4
JP−11 JP−27 LD 0F4, #i DRSZ
AND
A,[B]
A,#i
RPND JID AND
0F5
JP−10 JP−26 LD 0F5, #i DRSZ
XOR
A,[B]
A,#i
XOR
A,[B]
X A,[X] X
0F6
JP−9 JP−25 LD 0F6, #i DRSZ
* * OR A,#i OR
JP−8 JP−24 LD 0F7, #i DRSZ
A,[B]
0F7
NOP RLCA LD A,#i IFC SBIT
0F8
JP−7 JP−23 LD 0F8, #i DRSZ
IFNC SBIT
A,#i
IFNE
IFEQ
Md,#i
A,[B]
IFNE
0F9
JP−6 JP−22 LD 0F9, #i DRSZ
INCA SBIT
LD
[B+],#i
LD
A,[B+]
LD
A,[X+]
0FA
JP−5 JP−21 LD 0FA, #i DRSZ
DECA SBIT
LD
[B−],#i
LD
A,[B−]
LD
A,[X−]
0FB
JP−4 JP−20 LD 0FB, #i DRSZ
JMPL X A,Md POPA SBIT
LD
Md,#i
0FC
JP−3 JP−19 LD 0FC, #i DRSZ
RETSK SBIT
A,Md
DIR JSRL LD
0FD
JP−2 JP−18 LD 0FD, #i DRSZ
RET SBIT
LD
[B],#i
LD
A,[B]
LD
A,[X]
0FE
JP−1 JP−17 LD 0FE, #i DRSZ
* * LD B,#i RETI SBIT
0FF
JP−0 JP−16 LD 0FF, #i DRSZ
i is the immediate data
Where,
Md is a directly addressed memory location
* is an unused opcode
The opcode 60 Hex is also the opcode for IFBIT #i,A
Page 71

Mask Options
The COP684E and COP884EB mask programmable options
are shown below. The options are programmed at the same
time as the ROM pattern submission.
OPTION 1: CLOCK CONFIGURATION
= 1 Crystal Oscillator (CKI/10)
G7 (CKO) is clock generator output to crystal/
resonator
CKI is the clock input
OPTION 2: HALT
= 1 Enable HALT mode
OPTION 3: BONDING OPTIONS
= 1 68-Pin PLCC
= 2 44-Pin PLCC
The chip can be driven by a clock input on the CKI input pin
which can be between DC and 10 MHz. The CKO output
clock is on pin G7. The CKI input frequency is divided down
by 10 to produce the instruction cycle clock (1/t
).
c
Development Tools Support
OVERVIEW
National is engaged with an international community of independent 3rd party vendors who provide hardware and software development tool support. Through National’s interaction and guidance, these tools cooperate to form a choice of
solutions that fits each developer’s needs.
This section provides a summary of the tool and development kits currently available. Up-to-date information, selection guides, free tools, demos, updates, and purchase information can be obtained at our web site at:
www.national.com/cop8.
SUMMARY OF TOOLS
COP8 Evaluation Tools
COP8–NSEVAL: Free Software Evaluation package for
•
Windows. A fully integrated evaluation environment for
COP8, including versions of WCOP8 IDE (Integrated Development Environment), COP8-NSASM, COP8-MLSIM,
COP8C, DriveWay
information.
COP8–MLSIM: Free Instruction Level Simulator tool for
•
Windows. For testing and debugging software instructions only (No I/O or interrupt support).
COP8–EPU: Very Low cost COP8 Evaluation & Pro-
•
gramming Unit. Windows based evaluation and
hardware-simulation tool, with COP8 device programmer
and erasable samples. Includes COP8-NSDEV, Driveway COP8 Demo, MetaLink Debugger, I/O cables and
power supply.
COP8–EVAL-ICUxx: Very Low cost evaluation and de-
•
sign test board for COP8ACC and COP8SGx Families,
from ICU. Real-time environment with add-on A/D, D/A,
and EEPROM. Includes software routines and reference
designs.
Manuals,Applications Notes, Literature: Available free
•
from our web site at: www.national.com/cop8.
™
COP8, Manuals, and other COP8
COP8 Integrated Software/Hardware Design Development Kits
COP8-EPU: Very Low cost Evaluation & Programming
•
Unit. Windows based development and hardwaresimulation tool for COPSx/xG families, with COP8 device
programmer and samples. Includes COP8-NSDEV,
Driveway COP8 Demo, MetaLink Debugger, cables and
power supply.
COP8-DM: Moderate cost Debug Module from MetaLink.
•
A Windows based, real-time in-circuit emulation tool with
COP8 device programmer. Includes COP8-NSDEV,
DriveWay COP8 Demo, MetaLink Debugger, power supply, emulation cables and adapters.
COP8 Development Languages and Environments
COP8-NSASM: Free COP8 Assembler v5 for Win32.
•
Macro assembler, linker, and librarian for COP8 software
development. Supports all COP8 devices. (DOS/Win16
v4.10.2 available with limited support). (Compatible with
WCOP8 IDE, COP8C, and DriveWay COP8).
COP8-NSDEV: Very low cost Software Development
•
Package for Windows. An integrated development environment for COP8, including WCOP8 IDE, COP8NSASM, COP8-MLSIM.
COP8C: Moderately priced C Cross-Compiler and Code
•
Development System from Byte Craft (no code limit). Includes BCLIDE (Byte Craft Limited Integrated Development Environment) for Win32, editor, optimizing C CrossCompiler, macro cross assembler, BC-Linker, and
MetaLink tools support. (DOS/SUN versions available;
Compiler is installable under WCOP8 IDE; Compatible
with DriveWay COP8).
EWCOP8-KS: Very Low cost ANSI C-Compiler and Em-
•
bedded Workbench from IAR (Kickstart version:
COP8Sx/Fx only with 2k code limit; No FP). A fully integrated Win32 IDE, ANSI C-Compiler, macro assembler,
editor, linker, Liberian, C-Spy simulator/debugger, PLUS
MetaLink EPU/DM emulator support.
EWCOP8-AS: Moderately priced COP8 Assembler and
•
Embedded Workbench from IAR (no codelimit). A fully integrated Win32 IDE, macro assembler, editor, linker, librarian, and C-Spy high-level simulator/debugger with
I/O and interrupts support. (Upgradeable with optional
C-Compiler and/or MetaLink Debugger/Emulator support).
EWCOP8-BL: Moderately priced ANSI C-Compiler and
•
Embedded Workbench from IAR (Baseline version: All
COP8 devices; 4k code limit; no FP). A fully integrated
Win32 IDE, ANSI C-Compiler, macro assembler, editor,
linker,librarian, and C-Spyhigh-level simulator/debugger.
(Upgradeable; CWCOP8-M MetaLink tools interface support optional).
EWCOP8: Full featured ANSI C-Compiler and Embed-
•
ded Workbench for Windows from IAR (no code limit). A
fully integrated Win32 IDE, ANSI C-Compiler, macro assembler, editor, linker, librarian, and C-Spy high-level
simulator/debugger. (CWCOP8-M MetaLink tools interface support optional).
EWCOP8-M: Full featured ANSI C-Compiler and Embed-
•
ded Workbench for Windows from IAR (no code limit). A
fully integrated Win32 IDE, ANSI C-Compiler, macro assembler, editor, linker, librarian, C-Spy high-level
simulator/debugger, PLUS MetaLink debugger/hardware
interface (CWCOP8-M).
www.national.com71
Page 72

Development Tools Support
(Continued)
COP8 Productivity Enhancement Tools
WCOP8 IDE: Very Low cost IDE (Integrated Develop-
•
ment Environment) from KKD. Supports COP8C, COP8NSASM, COP8-MLSIM, DriveWay COP8, and MetaLink
debugger under a common Windows Project Management environment. Code development, debug, and emulation tools can be launched from the project window
framework.
DriveWay-COP8: Low cost COP8 Peripherals Code
•
Generation tool from Aisys Corporation. Automatically
generates tested and documented C or Assembly source
code modules containing I/O drivers and interrupt handlers for each on-chip peripheral. Application specific
code can be inserted for customization using the integrated editor. (Compatible with COP8-NSASM, COP8C,
and WCOP8 IDE.)
COP8-UTILS: Free set of COP8 assembly code ex-
•
amples, device drivers, and utilities to speed up code development.
COP8-MLSIM: Free Instruction Level Simulator tool for
•
Windows. For testing and debugging software instructions only (No I/O or interrupt support).
TOOLS ORDERING NUMBERS FOR THE COP888EB FAMILY DEVICES
Vendor Tools Order Number Cost Notes
National COP8-NSEVAL COP8-NSEVAL Free Web site download
COP8-NSASM COP8-NSASM Free Included in EPU and DM. Web site download
COP8-MLSIM COP8-MLSIM Free Included in EPU and DM. Web site download
COP8-NSDEV COP8-NSDEV VL Included in EPU and DM. Order CD from website
COP8-EPU Not available for this device
COP8-DM Contact MetaLink
Development
Devices
OTP
Programming
Adapters
IM-COP8 Contact MetaLink
MetaLink COP8-EPU Not available for this device
COP8-DM DM4-COP8-888EB (10
OTP
Programming
Adapters
IM-COP8 IM-COP8-AD-464 (-220)
IM Probe Card PC-888EB44P5-AD-10 M 10 MHz 44 PLCC probe card; 2.5V to 6.0V
ICU COP8-EVAL Not available for this device
KKD WCOP8-IDE WCOP8-IDE VL Included in EPU and DM
IAR EWCOP8-xx See summary above L - H Included all software and manuals
Byte
COP8C COP8C M Included all software and manuals
Craft
Aisys DriveWay COP8 DriveWay COP8 L Included all software and manuals
COP87L88EB/RB VL 16k or 32k OTP devices
EDI -44+68PL/40DZAL-W-COP888EB
MHz), plus PS-10, plus
DM-COP8/xxx (ie. 44P)
EDI -44/68PL/40DZAL-W-COP888EB
(10 MHz maximum)
PC-888EB68P5-AD-10 M 10 MHz 68 PLCC probe card; 2.5V to 6.0V
COP8 Real-Time Emulation Tools
COP8-DM: MetaLink Debug Module. A moderately
•
priced real-time in-circuit emulation tool, with COP8 device programmer. Includes COP8-NSDEV, DriveWay
COP8 Demo, MetaLink Debugger, power supply, emulation cables and adapters.
IM-COP8: MetaLink iceMASTER®. A full featured, real-
•
time in-circuit emulator for COP8 devices. Includes MetaLink Windows Debugger, and power supply. Packagespecific probes and surface mount adaptors are ordered
separately.
COP8 Device Programmer Support
MetaLink’s EPU and Debug Module include development
•
device programming capability for COP8 devices.
Third-party programmers and automatic handling equip-
•
ment cover needs from engineering prototype and pilot
production, to full production environments.
Factory programming available for high-volume require-
•
ments.
L For programming 44/68 PLCC on any programmer.
Contact EDI
M Included p/s (PS-10), target cable of choice (PLCC;
i.e. DM-COP8/40P), EDI 44/68 PLCC OTP adapter
L For programming 44/68 PLCC
H Base unit 10 MHz; -220 = 220V; add probe card
(required) and target adapter (if needed); included
software and manuals
www.national.com 72
Page 73
Development Tools Support (Continued)
OTP Programmers Contact vendors L - H For approved programmer listings and vendor
information, go to our OTP support page at:
www.national.com/cop8
<
Cost: Free; VL =
$100; L = $100 - $300; M = $300 - $1k; H = $1k - $3k; VH = $3k - $5k
WHERE TO GET TOOLS
Tools are ordered directly from the following vendors. Please go to the vendor’s web site for current listings of distributors.
Vendor Home Office Electronic Sites Other Main Offices
Aisys U.S.A.: Santa Clara, CA www.aisysinc.com Distributors
1-408-327-8820 info
@
aisysinc.com
fax: 1-408-327-8830
Byte Craft U.S.A. www.bytecraft.com Distributors
1-519-888-6911 info
@
bytecraft.com
fax: 1-519-746-6751
IAR Sweden: Uppsala www.iar.se U.S.A.: San Francisco
+46 18 16 78 00 info
fax: +46 18 16 78 38 info
@
iar.se 1-415-765-5500
@
iar.com fax: 1-415-765-5503
@
info
iarsys.co.uk U.K.: London
@
info
iar.de +44 171 924 33 34
fax: +44 171 924 53 41
Germany: Munich
+49 89 470 6022
fax: +49 89 470 956
ICU Sweden: Polygonvaegen www.icu.se Switzeland: Hoehe
+46 8 630 11 20 support
fax: +46 8 630 11 70 support
@
icu.se +41 34 497 28 20
@
icu.ch fax: +41 34 497 28 21
KKD Denmark: www.kkd.dk
MetaLink U.S.A.: Chandler, AZ www.metaice.com Germany: Kirchseeon
1-800-638-2423 sales
fax: 1-602-926-1198 support
@
metaice.com 80-91-5696-0
@
metaice.com fax: 80-91-2386
bbs: 1-602-962-0013 islanger
@
metalink.de
www.metalink.de Distributors Worldwide
National U.S.A.: Santa Clara, CA www.national.com/cop8 Europe: +49 (0) 180 530 8585
1-800-272-9959 support
fax: 1-800-737-7018 europe.support
The following companies have approved COP8 programmers in a variety of configurations. Contact your local office
or distributor. You can link to their web sites and get the latest listing of approved programmers from National’s COP8
OTP Support page at: www.national.com/cop8.
@
nsc.com fax: +49 (0) 180 530 8586
@
nsc.com Distributors Worldwide
Customer Support
Complete product information and technical support is available from National’s customer response centers, and from
our on-line COP8 customer support sites.
Advantech; Advin; BP Microsystems; Data I/O; Hi-Lo Systems; ICE Technology; Lloyd Research; Logical Devices;
MQP; Needhams; Phyton; SMS; Stag Programmers; System General; Tribal Microsystems; Xeltek.
www.national.com73
Page 74
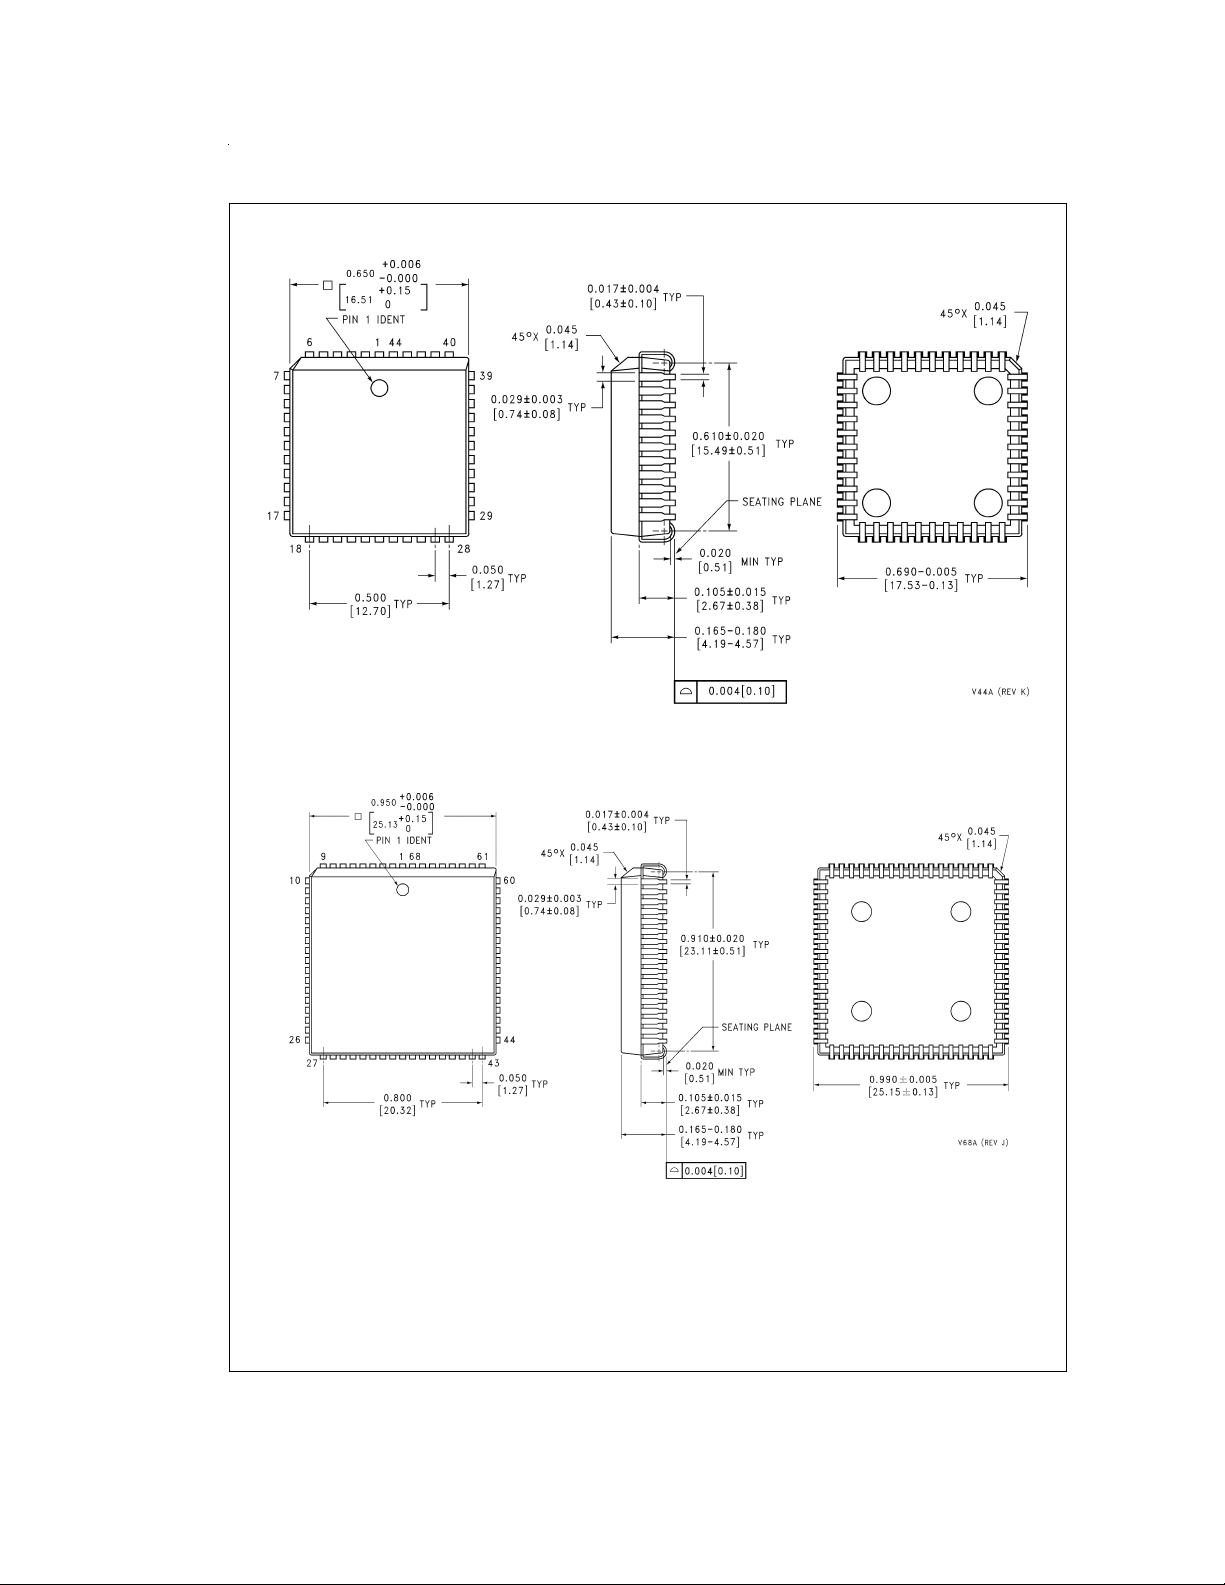
Physical Dimensions inches (millimeters) unless otherwise noted
44-Lead Molded Plastic Leaded Chip Carrier
Order Number COP888EB-XXX/V, COP688EB-XXX/V
NS Plastic Chip Package Number V44A
68-Lead Molded Plastic Leaded Chip Carrier
Order Number COP889EB-XXX/V, COP689EB-XXX/V
NS Plastic Chip Package Number V68A
www.national.com 74
Page 75
Notes
COP888EB 8–Bit CMOS ROM Based Microcontrollers with 8k Memory, CAN Interface, 8–Bit A/D,
and USART
LIFE SUPPORT POLICY
NATIONAL’S PRODUCTS ARE NOT AUTHORIZED FOR USE AS CRITICAL COMPONENTS IN LIFE SUPPORT
DEVICES OR SYSTEMS WITHOUT THE EXPRESS WRITTEN APPROVAL OF THE PRESIDENT AND GENERAL
COUNSEL OF NATIONAL SEMICONDUCTOR CORPORATION. As used herein:
1. Life support devices or systems are devices or
systems which, (a) are intended for surgical implant
into the body, or (b) support or sustain life, and
whose failure to perform when properly used in
accordance with instructions for use provided in the
2. A critical component is any component of a life
support device or system whose failure to perform
can be reasonably expected to cause the failure of
the life support device or system, or to affect its
safety or effectiveness.
labeling, can be reasonably expected to result in a
significant injury to the user.
National Semiconductor
Corporation
Americas
Tel: 1-800-272-9959
Fax: 1-800-737-7018
Email: [email protected]
www.national.com
National does not assume any responsibility for use of any circuitry described, no circuit patent licenses are implied and National reserves the right at any time without notice to change said circuitry and specifications.
National Semiconductor
Europe
Fax: +49 (0) 1 80-530 85 86
Email: [email protected]
Deutsch Tel: +49 (0) 1 80-530 85 85
English Tel: +49 (0) 1 80-532 78 32
Français Tel: +49 (0) 1 80-532 93 58
Italiano Tel: +49 (0) 1 80-534 16 80
National Semiconductor
Asia Pacific Customer
Response Group
Tel: 65-2544466
Fax: 65-2504466
Email: [email protected]
National Semiconductor
Japan Ltd.
Tel: 81-3-5639-7560
Fax: 81-3-5639-7507
 Loading...