

Page 1
ROBOT . HEAD to TOE
Product User’s Manual – MD13S
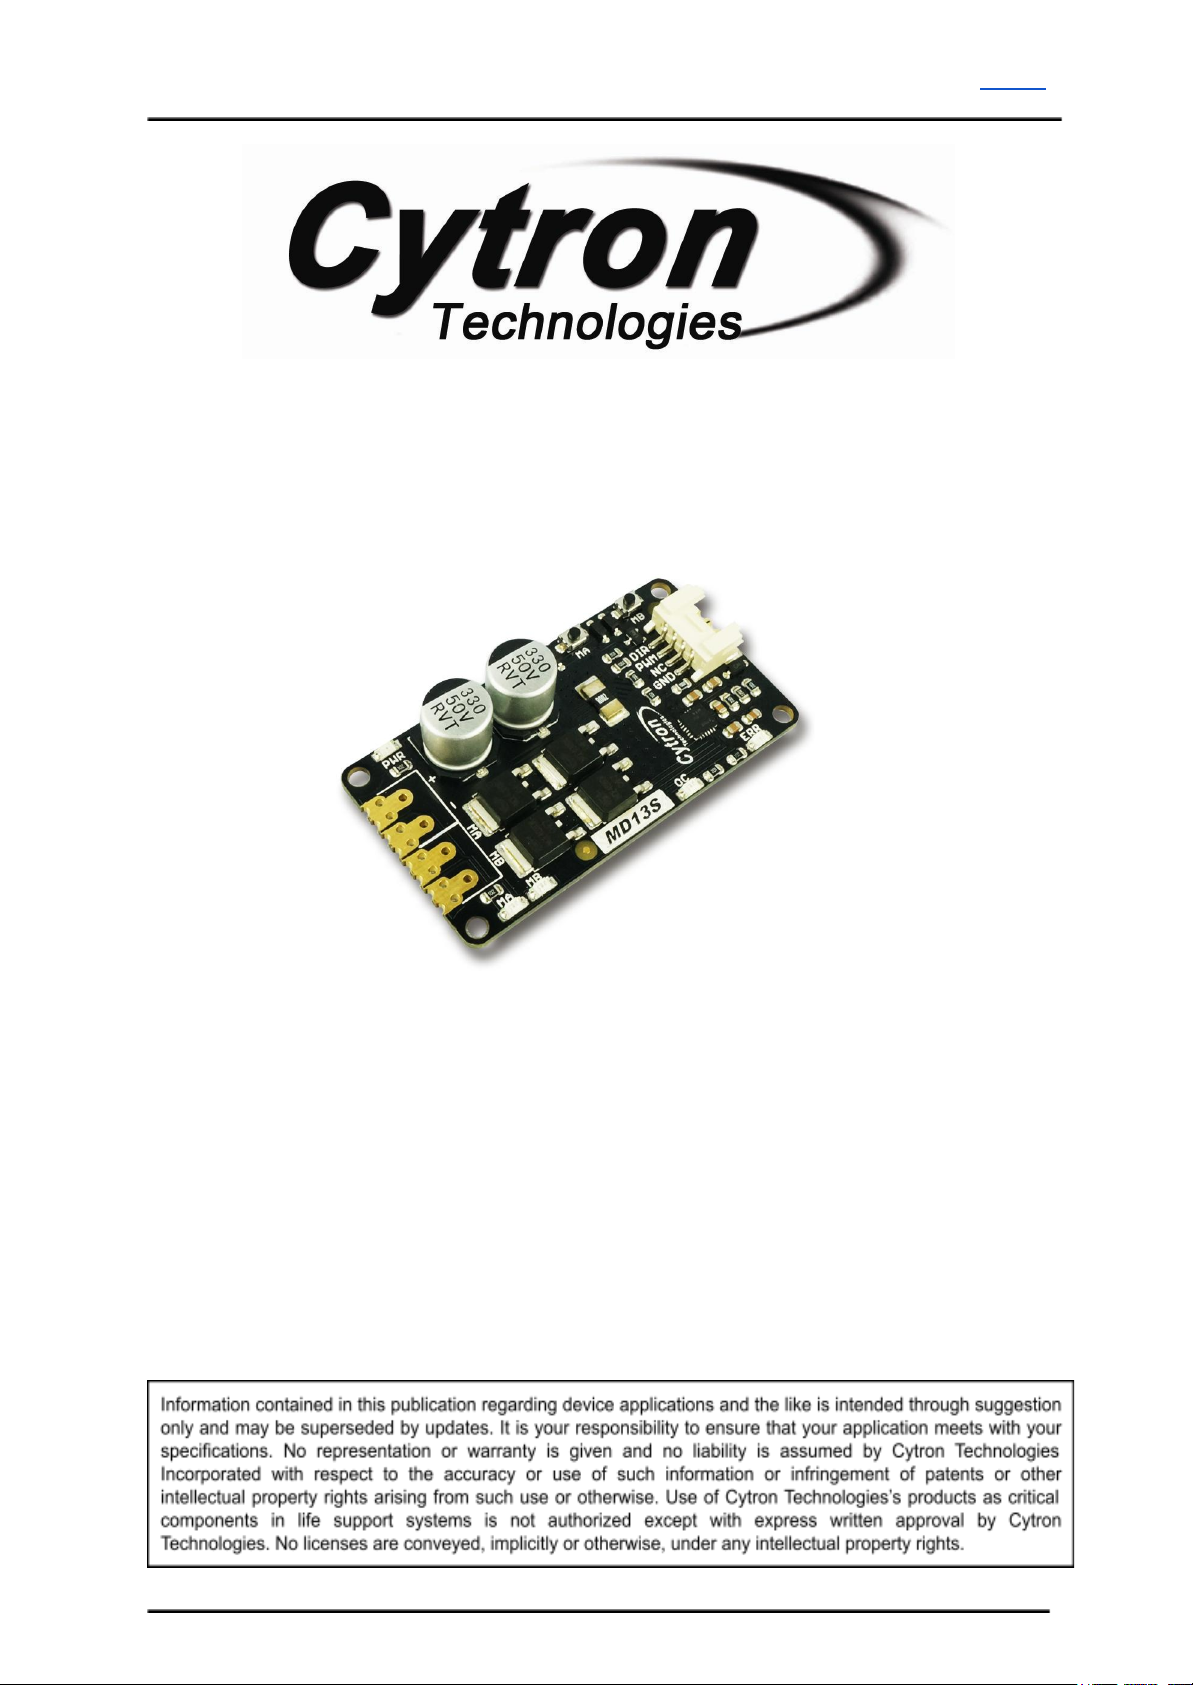
MD13S
13Amp DC Motor Driver
User's Manual
V1.1
June 2018
Created by Cytron Technologies Sdn. Bhd. – All Rights Reserved 1
Page 2
ROBOT . HEAD to TOE
Product User’s Manual – MD13S
INDEX
1. Introduction/Overview 3
2. Packing List 4
3. Board Layout 5
4. Product Specification 7
5. Dimension 8
6. Getting Started 9
7. Warranty 10
Created by Cytron Technologies Sdn. Bhd. – All Rights Reserved 2
Page 3
ROBOT . HEAD to TOE
Product User’s Manual – MD13S
1. INTRODUCTION/OVERVIEW
MD13S is designed to drive high current brushed DC motor up to 13A continuously. It offers
several enhancements such as support for both locked-antiphase and sign-magnitude PWM
signal because it uses full solid state components which is able to provide faster response
time and eliminate the wear and tear of the mechanical relay.
The MD13S has been designed with the capabilities and features of:
● Bi-directional control for one brushed DC motor.
● Support motor voltage ranges from 6V to 30V.
● Maximum current up to 13A continuous (without heatsink at 25℃) and 30A peak (10
second).
● Current limiting at 30A.
● 3.3V and 5V logic level input.
● GROVE compatible connector.
● Solid state components provide faster response time and eliminate the wear and tear
of mechanical relay.
● Fully NMOS H-Bridge for better efficiency and no heat sink is required.
● Speed control PWM frequency up to 20KHz (Actual output frequency is same as
input frequency).
● Support both locked-antiphase and sign-magnitude PWM operation.
● Support TTL PWM from microcontroller, not PWM from RC receiver.
● SMD Compatible
● Dimension:61mm x 33mm
Created by Cytron Technologies Sdn. Bhd. – All Rights Reserved 3
Page 4
ROBOT . HEAD to TOE
Product User’s Manual – MD13S
2. PACKING LIST
Please check the parts and components according to the packing list. If there are any parts
missing, please contact us at [email protected] immediately.
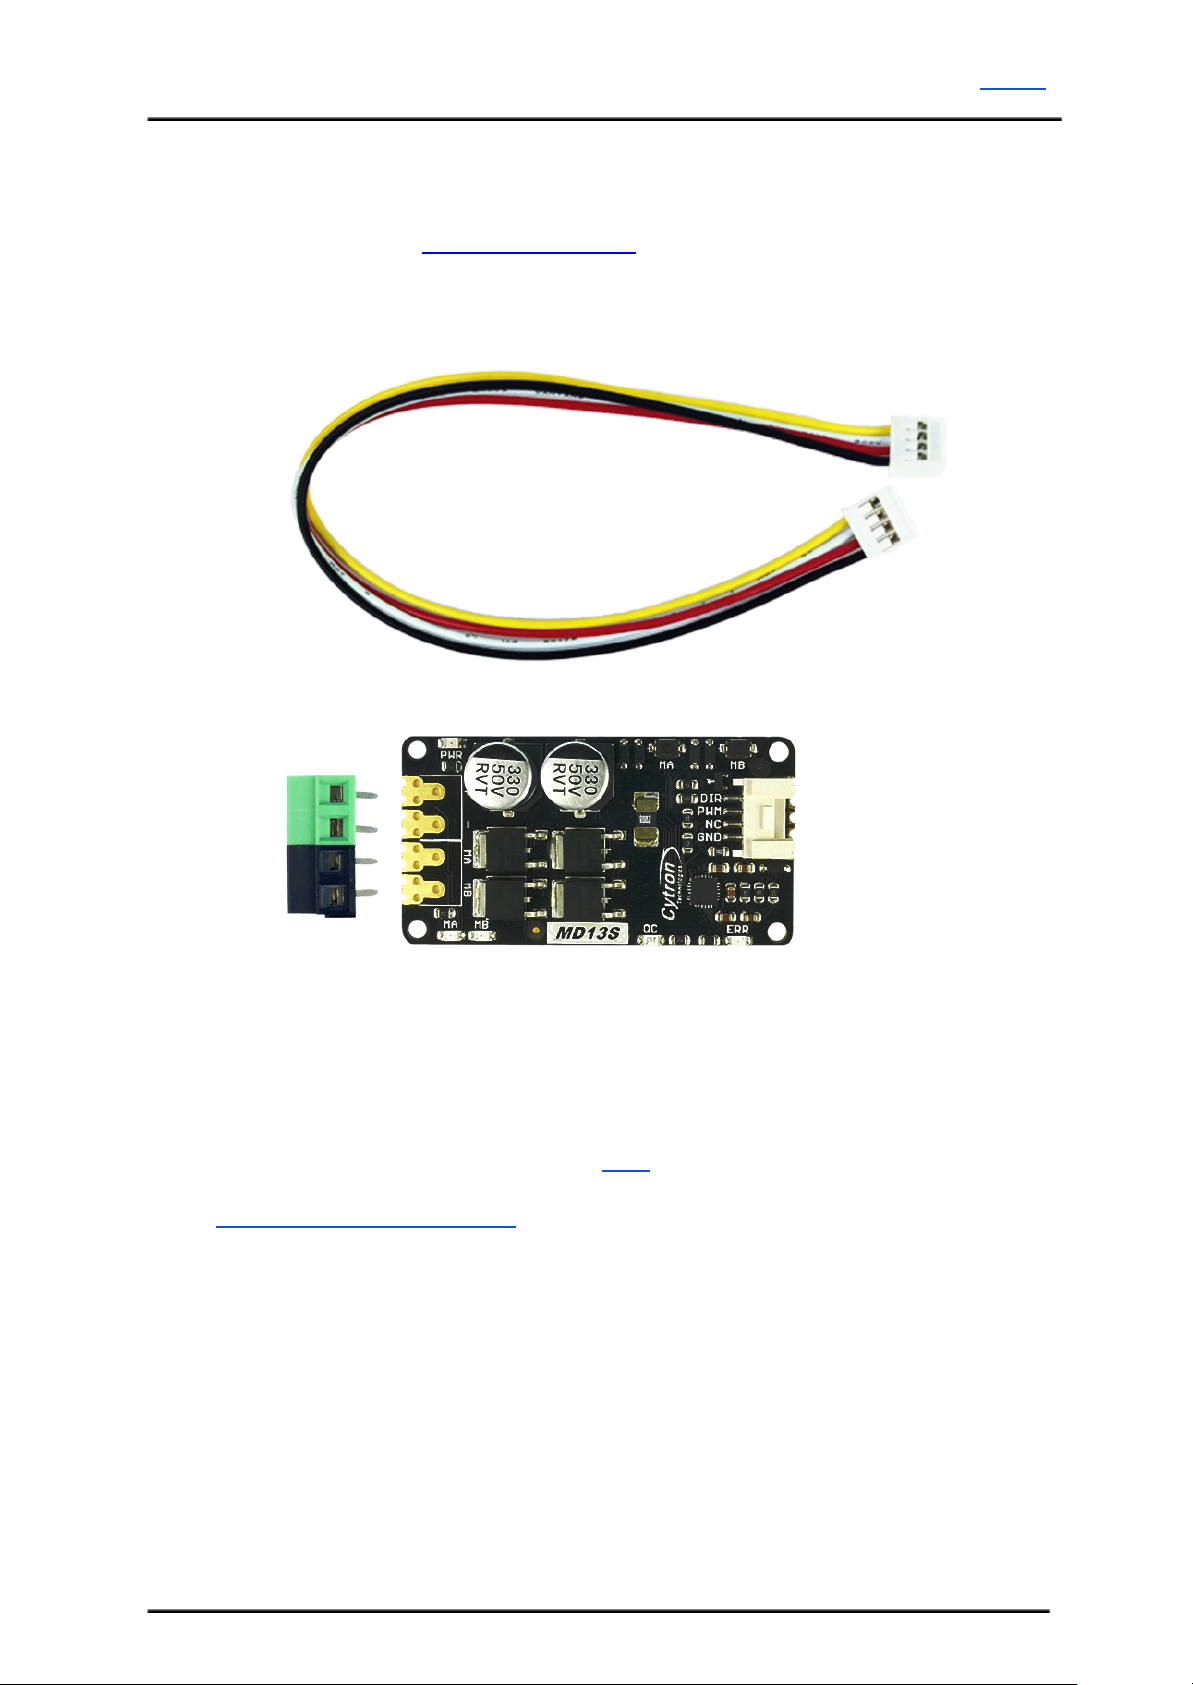
1. 1 x MD13S 13A DC Motor Driver.
2. 2 x Terminal socket, Black for power and Green for Motor.
3. Grove connector with cable.
4. User’s manual can be downloaded from here
5. If you like to get MD13S, please get it from our online store here:
https://www.cytron.io/p-md13s
Created by Cytron Technologies Sdn. Bhd. – All Rights Reserved 4
Page 5
ROBOT . HEAD to TOE
Product User’s Manual – MD13S
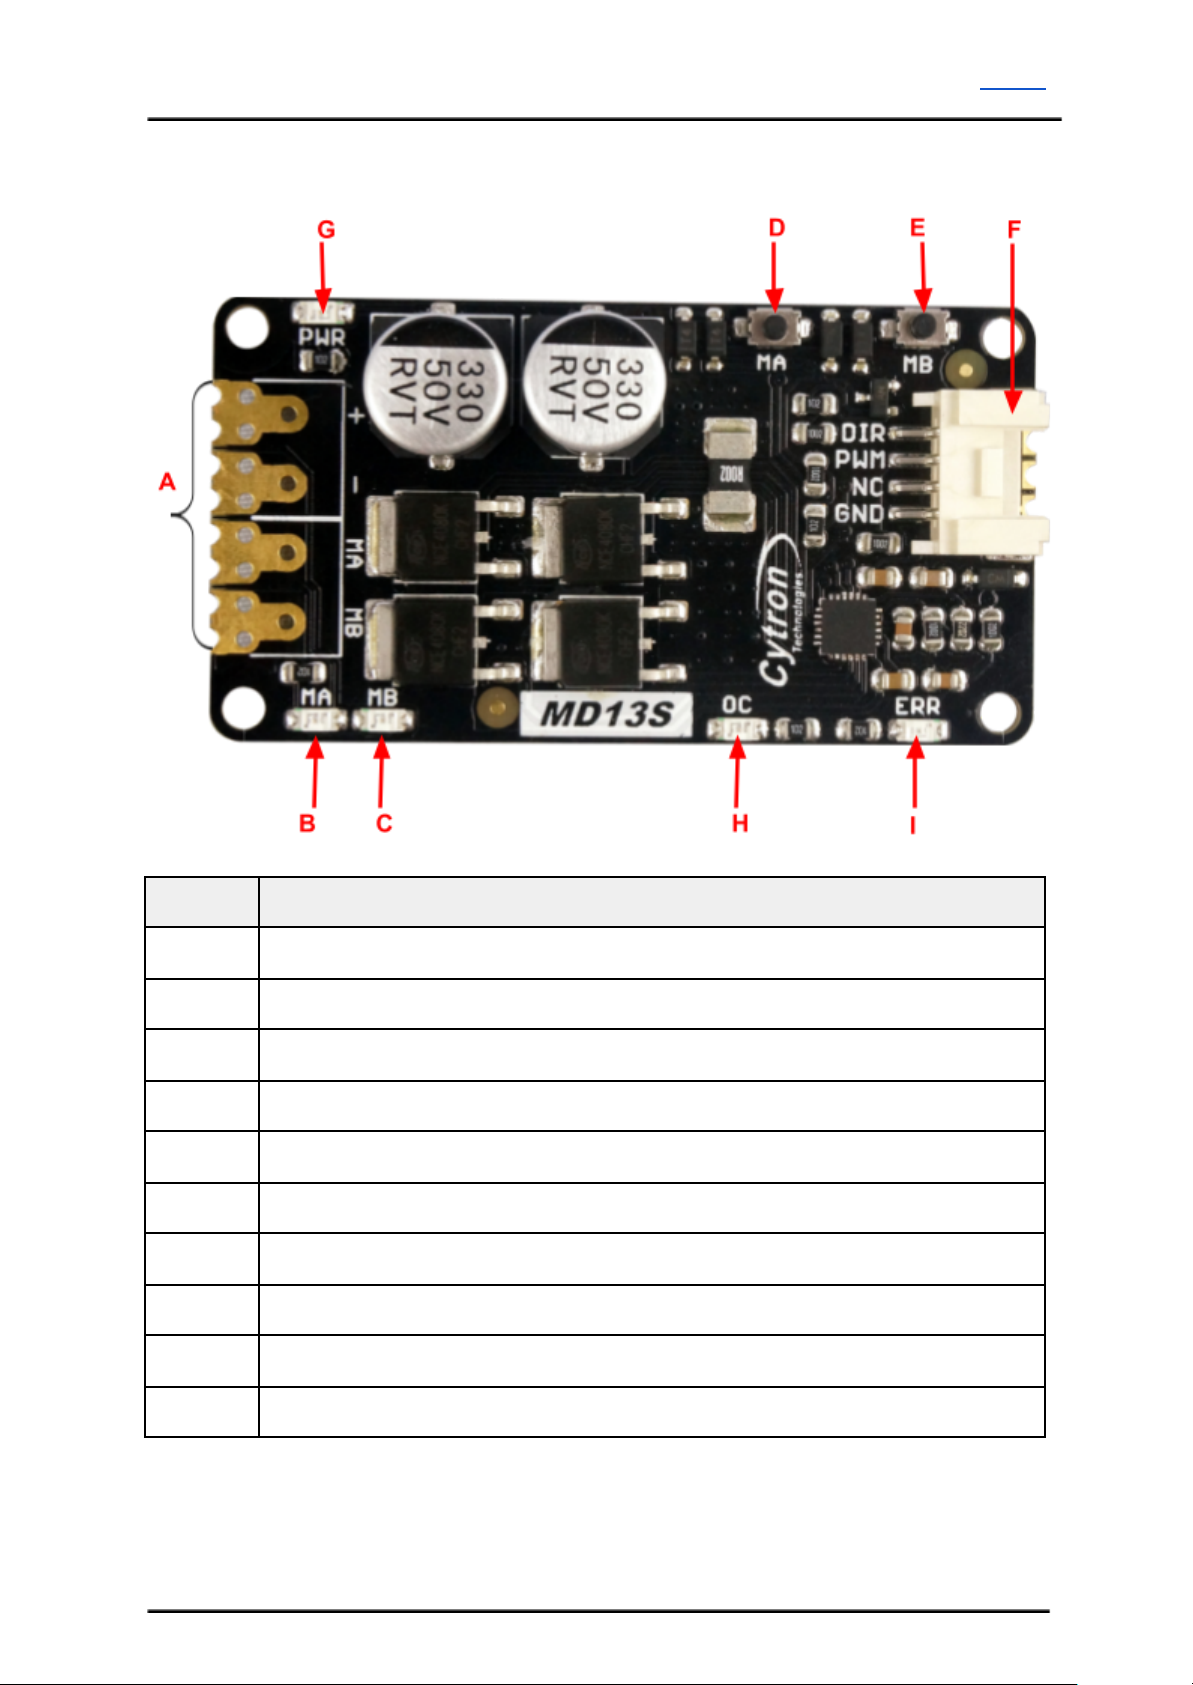
3. BOARD LAYOUT AND SPECIFICATION
Label
Function
A
Terminal Block
B
MA LED Indicator
C
MB LED Indicator
D
MA Test Switch
E
MB Test Switch
F
Input pin
G
Power LED Indicator
H
OC LED Indicator
I
ERR LED Indicator
J
SMD Compatible
Created by Cytron Technologies Sdn. Bhd. – All Rights Reserved 5
Page 6
ROBOT . HEAD to TOE
Product User’s Manual – MD13S
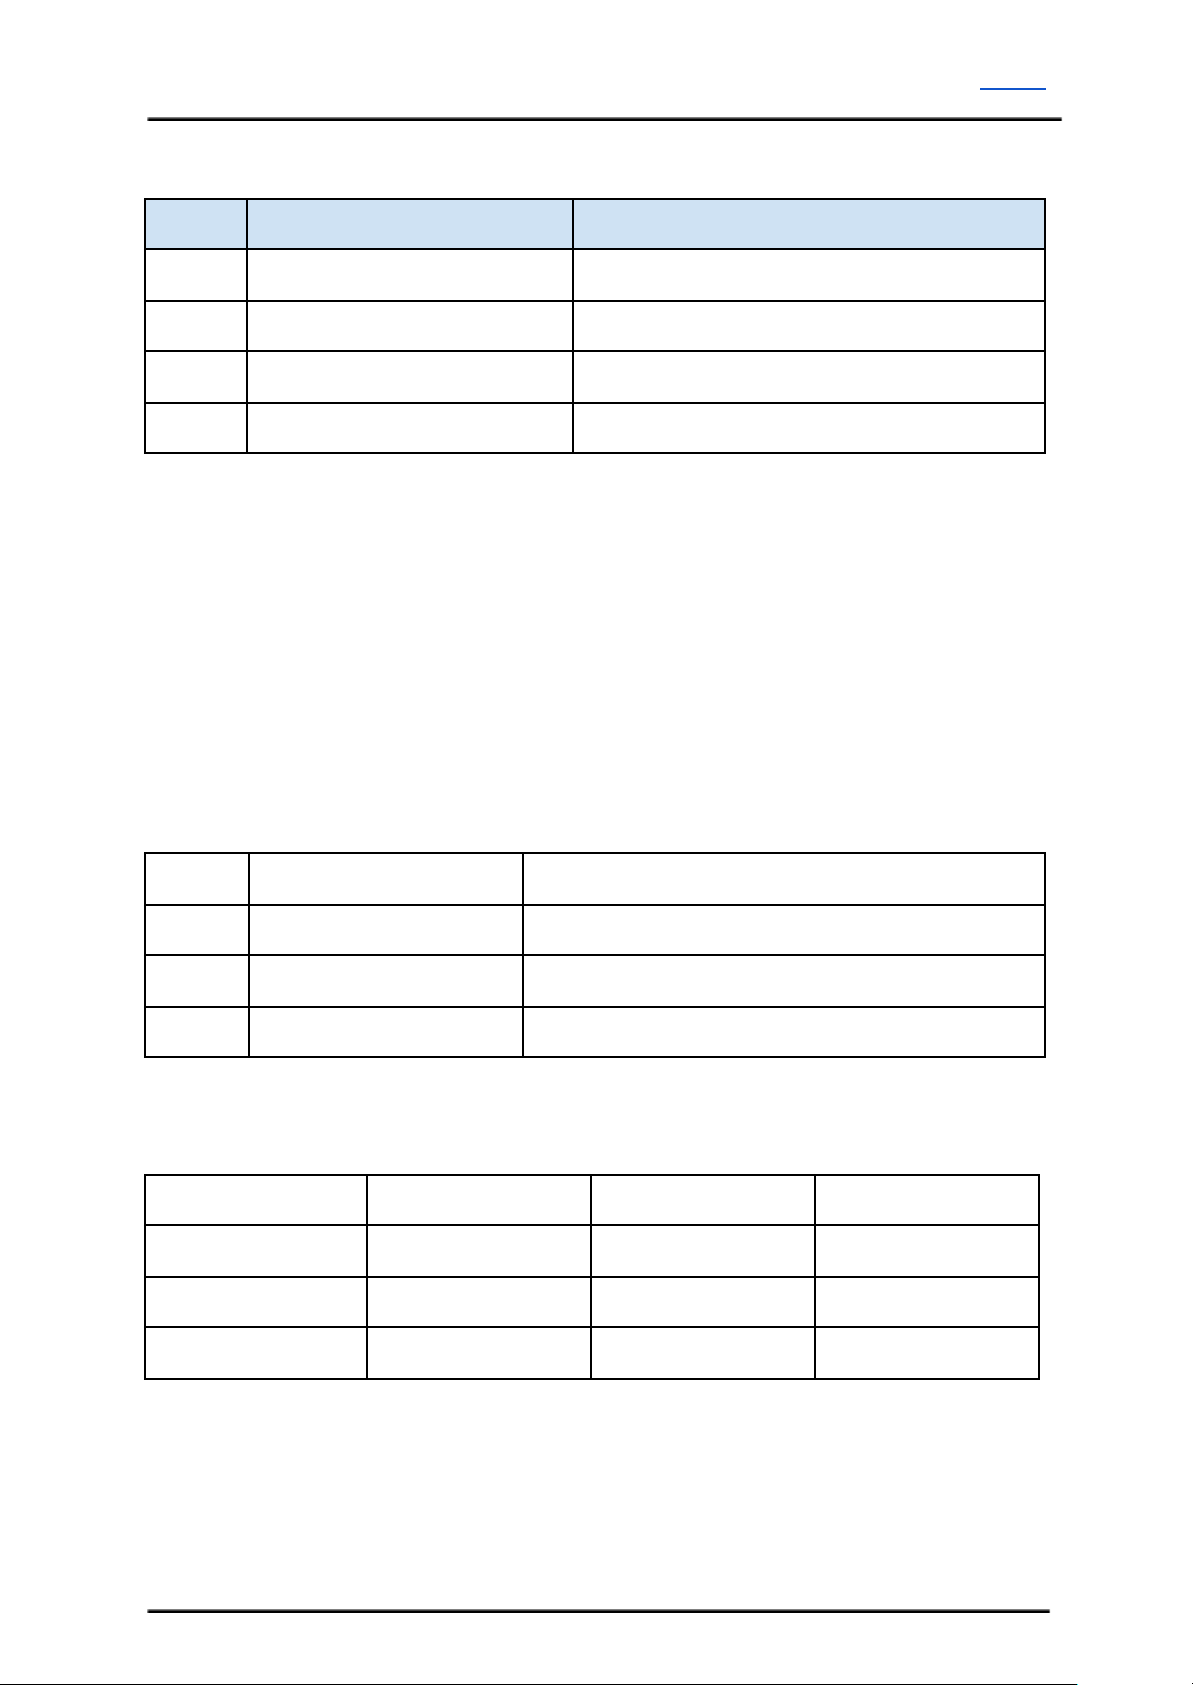
1. Terminal Block – Connect to motor and power source.
Pin No.
Pin Name
Description
1
POWER +
Positive Supply (6V to 30V)
2
POWER -
Negative Supply
3
Motor Output A
Connect to motor terminal A
4
Motor Output B
Connect to motor terminal B
2. MA LED Indicator – Turns on when the output A is high and output B is low. Indicates the
current flows from output A to B.
3. MB LED Indicator – Turns on when the output A is low and output B is high. Indicates the
current flows from output B to A.
4. MA Test Switch – When this button is pressed, current flows from output A to B and
motor will turn CW (or CCW depending on the connection).
5. MB Test Switch – When this button is pressed, current flows from output B to A and
motor will turn CCW (or CW depending on the connection).
6. Input
Pin No.
Pin Name
Description
1
GND
Logic ground.
2
**PWM
PWM input for speed control
3
DIR
Direction control.
**Note that it is not for RC PWM operation
The truth table for the control logic is as follow:
Pin 2 (PWM)
Pin 3 (DIR)
Output A
Output B
Low
X (Don’t care)
Low
Low
High
Low
High
Low
High
High
Low
High
7. Power LED Indicator – Power LED. Should be on when the board is powered on.
8. OC (Over Current)LED Indicator, Output current is over 30A limit.
9. ERR LED Indicator - Error LED Indicator, it will illuminate when fault detected in on
board MOSFET driver.
10. SMD compatible
Created by Cytron Technologies Sdn. Bhd. – All Rights Reserved 6
Page 7
ROBOT . HEAD to TOE
Product User’s Manual – MD13S
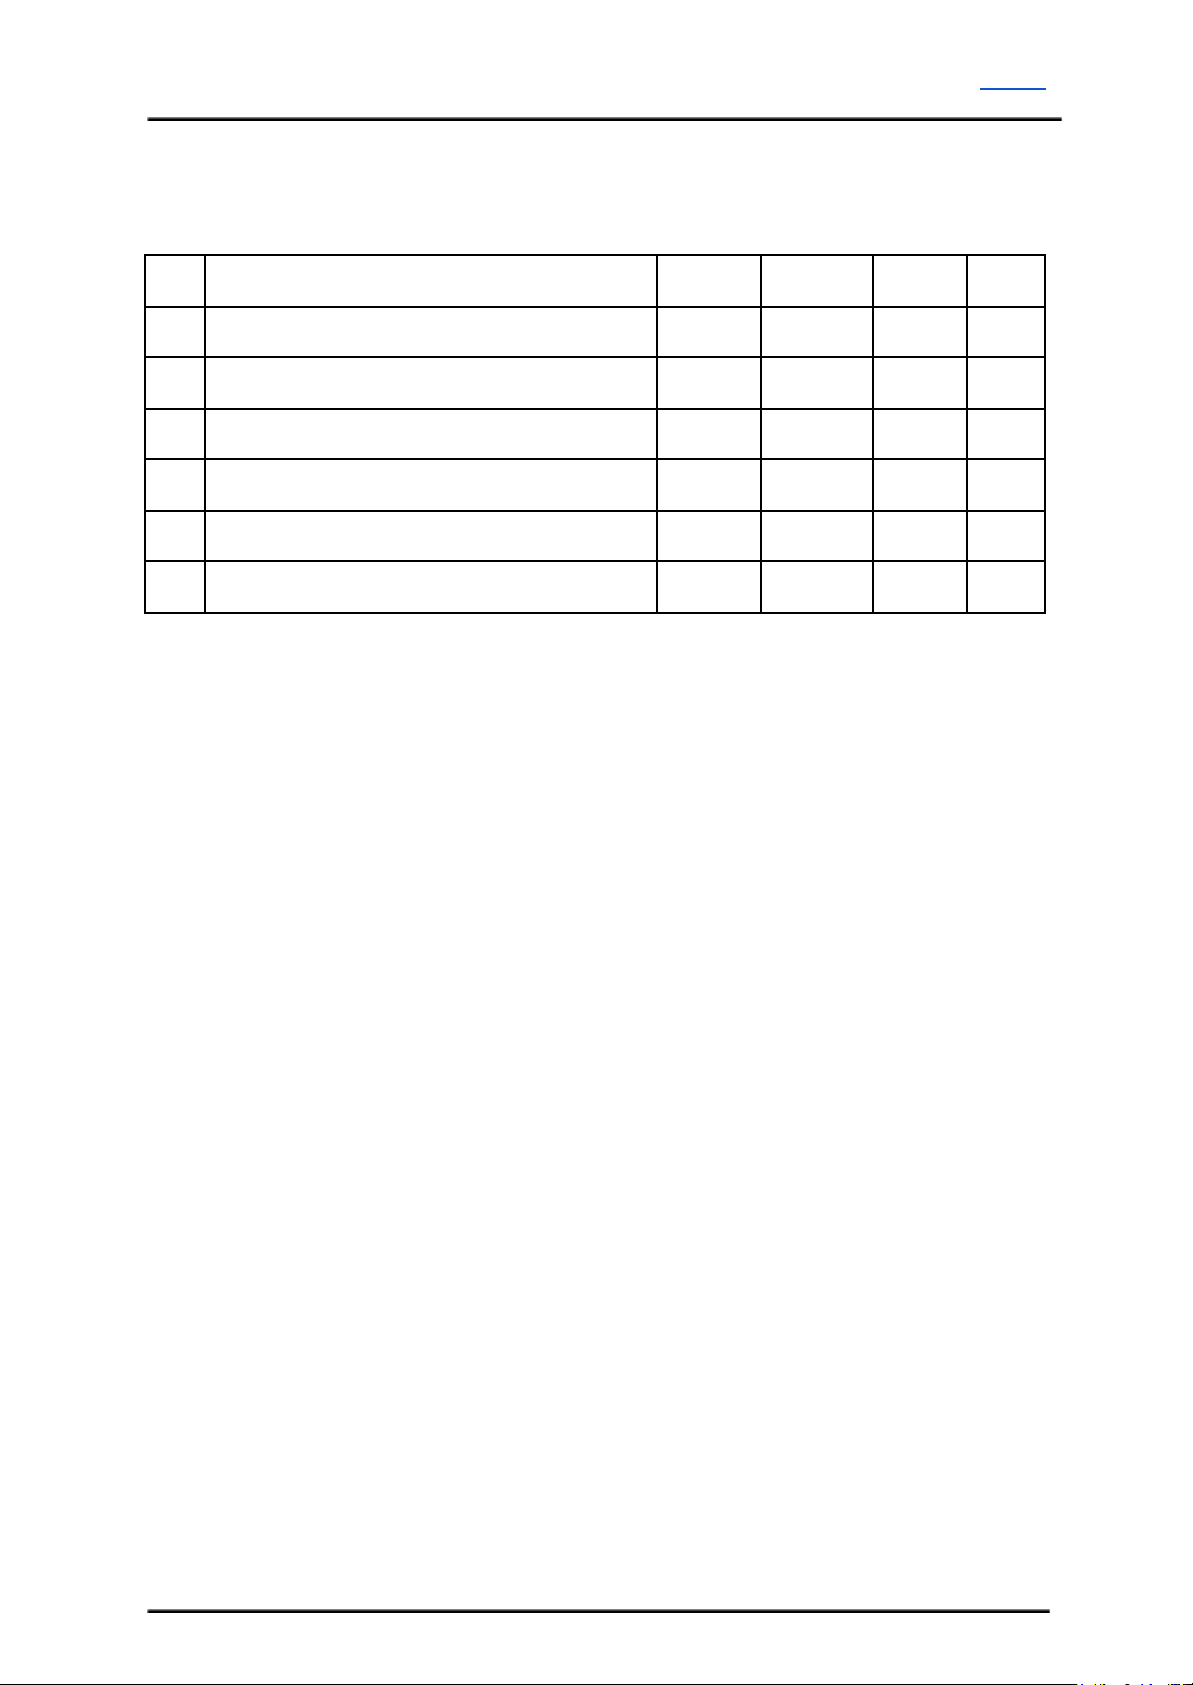
4. PRODUCT SPECIFICATION AND LIMITATIONS
Absolute Maximum Rating
No.
Parameters
Min
Typical
Max
Unit
1
Power Input Voltage
6-30V2
I
MAX
(Maximum Continuous Motor Current)
--13A3
I
PEAK
– (Peak Motor Current) *
--30A4
V
IOH
(Logic Input – High Level)
3-5.5V5
V
IOL
(Logic Input – Low Level)
000.5V6
Maximum PWM Frequency **
--20
KHz
* Must not exceed 10 seconds.
** Actual output frequency is same as input frequency.
*** Tested in room temperature.
Created by Cytron Technologies Sdn. Bhd. – All Rights Reserved 7
Page 8
ROBOT . HEAD to TOE
Product User’s Manual – MD13S
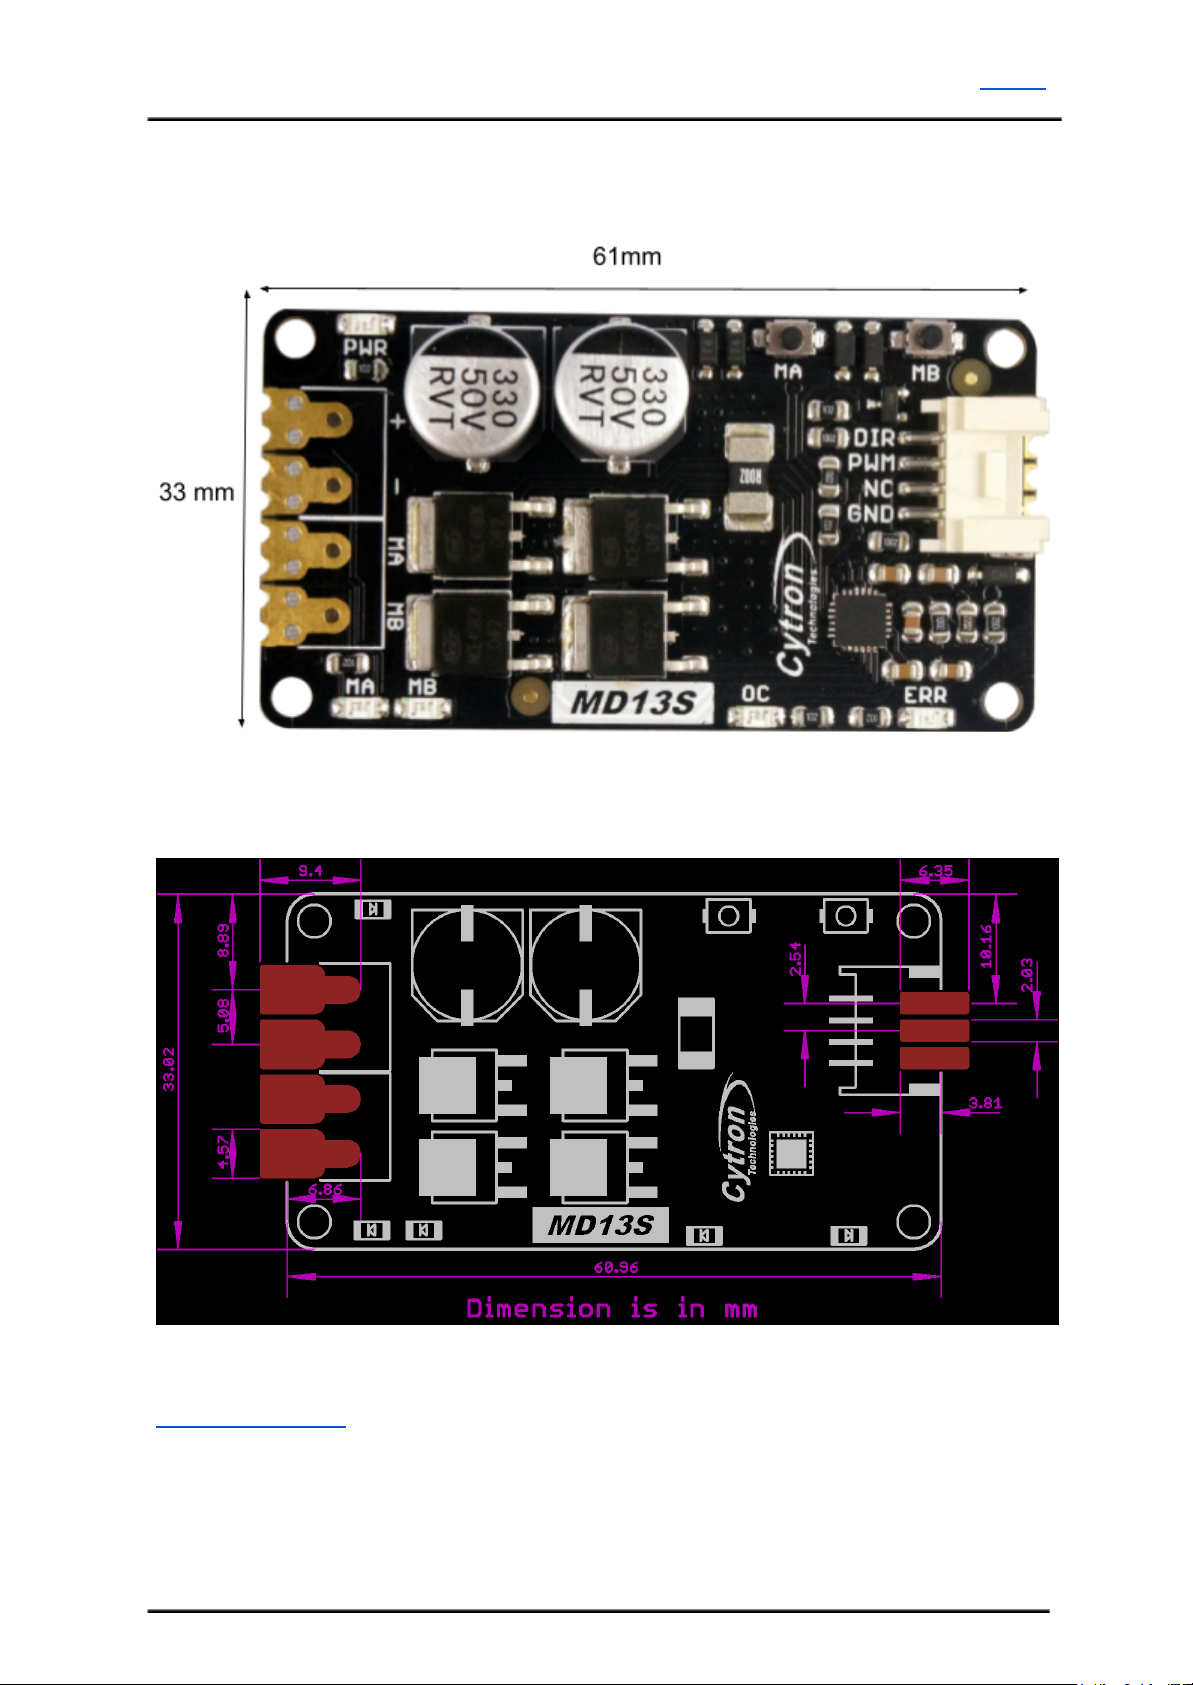
5. DIMENSION
Footprint Dimension
*Eagle CAD Library
Created by Cytron Technologies Sdn. Bhd. – All Rights Reserved 8
Page 9
ROBOT . HEAD to TOE
Product User’s Manual – MD13S
6. GETTING STARTED
MD13S is compatible with 2 types of PWM operation, which are:
1. Sign-Magnitude PWM – For sign-magnitude PWM operation, 2 control signals are used to
control the speed and direction of the motor. PWM is feed to the PWM pin to control the
speed while DIR pin is used to control the direction of the motor.
2. Locked-Antiphase PWM – For locked-antiphase PWM operation, only 1 control signal is
needed to control the speed and direction of the motor. PWM pin is connected to logic high
while the DIR pin is being feed with the PWM signal. When the PWM signal has 50% duty
cycle, the motor stops running. If the PWM has less than 50% duty cycle, the motor will turn
CW (or CCW depending on the connection). If the PWM signal has more than 50% duty
cycle, motor will turn CCW (or CW depending on the connection).
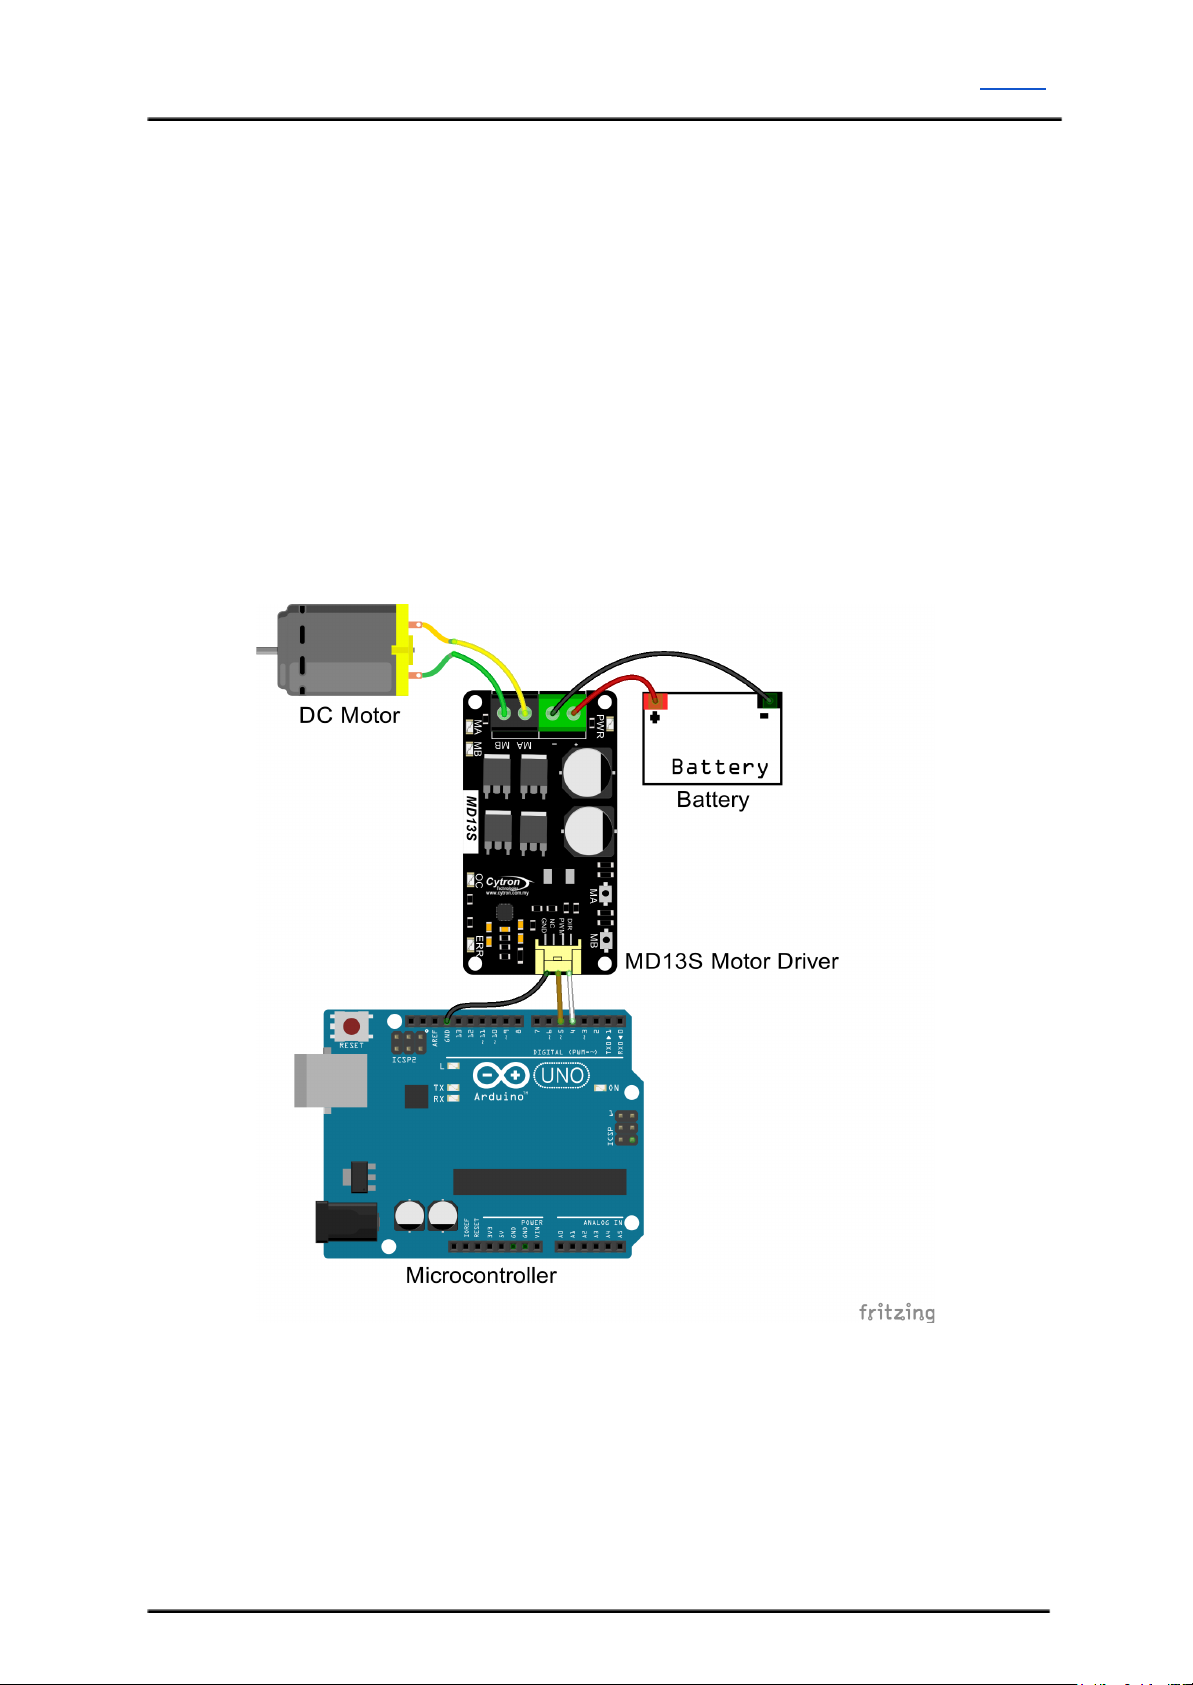
Sample connection diagram is as follow:
Created by Cytron Technologies Sdn. Bhd. – All Rights Reserved 9
Page 10
ROBOT . HEAD to TOE
Product User’s Manual – MD13S
7. WARRANTY
● Product warranty is valid for 12 months.
● Warranty only applies to manufacturing defect.
● Damaged caused by misuse is not covered under warranty
● Warranty does not cover freight cost for both ways.
Prepared by:
Cytron Technologies Sdn. Bhd.
No. 1, Lorong Industri Impian 1,
Taman Industri Impian,
14000 Bukit Mertajam,
Penang, Malaysia.
Google Maps
Tel: +604-548 0668
Fax: +604-548 0669
URL: www.cytron.io
Email: [email protected]
Created by Cytron Technologies Sdn. Bhd. – All Rights Reserved 10
 Loading...