

Page 1
Installation & Operation Manual
COMPLIES WITH
PBN 29010078 v1.6
C
E REGULATION
S
Vector G1 GPS
Satellite Compass
Installation & Operation Manual
PN 29010087 v1.0
COMPLIES WITH
CE REGULATIONS
Page 2
This device complies with part 15 of the FCC Rules. Operation is subject to the following two
conditions:
(1) This device may not cause harmful interference, and
(2) this device must accept any interference received, including interference that may cause undesired
operation.
Copyright Notice
No part of this manual may be reproduced, transmitted, transcribed, stored in a retrieval system or
translated into any language or computer language, in any form or by any means, electronic,
mechanical, magnetic, optical, chemical, manual or otherwise, without the prior written permission of
ComNav Marine Ltd.
i
Page 3
Chapter 1: Introduction
Overview
Parts List
1
1
Page 4
2
Page 5

Chapter 1: Introduction
Overview
Note: Throughout this manual, the Vector G1 GPS Compass is referred to simply as the G1.
The G1 is a complete GPS compass and positioning system in a single enclosure that requires only one
power/data cable connection. With its CAN support and ease of installation, the G1 is the perfect solution
for both marine and land base applications such as mine construction, earthworks and machine guidance.
The G1 is an integrated system that houses the following:
The gyro and tilt sensors are present to improve system performance and to provide backup heading
information in the event that a GPS heading is not available due to signal blockage.
Crescent technology supports multiple RF front ends - enabling tighter coupling of measurements from
separate antennas for use in heading-based products. Users will achieve excellent accuracy and stability due
to Crescent’s more accurate code phase measurements, improved multipath mitigation, and fewer
components.
• Crescent Vector II technology
• Dual integrated GPS antennas
• Power supply
• Single axis gyro
• Tilt sensors (two)
The G1’s GPS antennas are separated by 27 cm between their phase centers, resulting in better than 0.60°
rms heading performance. The G1 provides heading and positioning updates of up to 20 Hz and delivers
positioning accuracy of better than 1.0 m 95% of the time when using differential GPS corrections from
Space Based Augmentation Systems (SBAS).
The G1 GPS receivers may utilize old differential GPS correction data for 40 minutes or more without
significantly affecting the positioning quality. The G1 is less likely to be affected by differential signal
outages due to signal blockages, weak signals, or interference when using COAST.
If you are new to GPS and SBAS, refer to the GPS Technical Reference for further information on these
services and technologies before proceeding.
Parts List
Note: The G1’s parts comply with IEC 60945 Section 4.4: “exposed to the weather.”
Part Name Qty Part Number
G1 receiver 1 31210010
Power/data cable, 15 m (accessory item)* 1 31110053
Serial-to-NMEA 2000 adapter 1 31210011
ComNav Tool Kit CD 1 29030052
User Manual 1 29010087
*Note: if G1 system Part number 11210029 was ordered, use cable part number
31110052 for serial adapter 31210011, rather than cable part number 31110053.
Table 1-1: Parts list
3
2
Page 6
4
Page 7
Chapter 2: Installation
Mounting Location
Mounting Orientation
Mounting Options
Powering the G1
Connecting the G1 to External Devices
5
4
Page 8
6
Page 9
Chapter 2: Installation
Mounting Location
This section provides information on determining the best location for the G1.
Note: Mounting Template available -Vector G1 Satellite Compass part number 29030054
GPS Reception
When considering where to mount the G1, consider the following GPS reception recommendations:
• Consider GPS (and hence SBAS) reception, ensuring there is a clear view of the sky available to
the G1 so the GPS and SBAS satellites are not masked by obstructions that may reduce system
performance
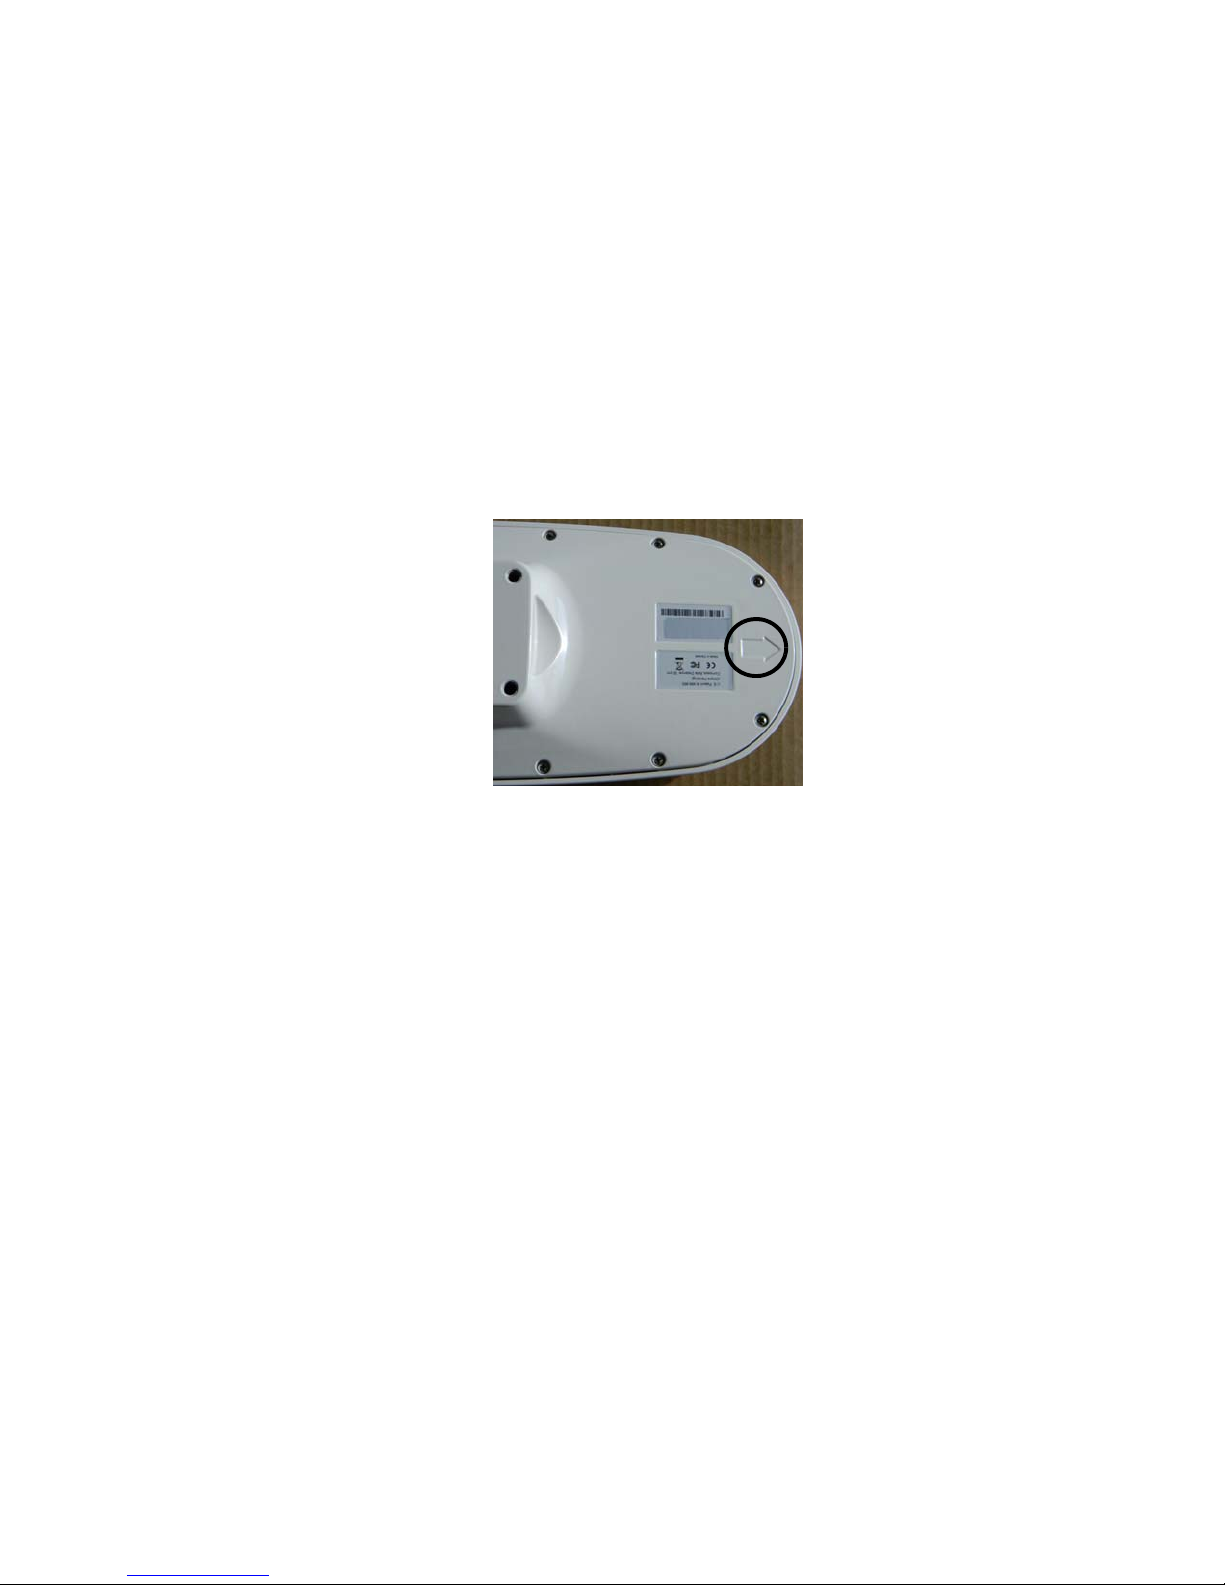
• Since the G1 computes a position based on the internal primary GPS antenna element, mount the
G1 where you desire a position with respect to the primary GPS antenna (located on the end
opposite the recessed arrow on the underside of the enclosure)
• Locate any transmitting antennas away from the G1 by at least a several feet to ensure tracking
performance is not compromised, giving you the best performance possible
• Make sure there is enough cable length to route into the vessel to reach a breakout box or terminal
strip
• Do not locate the antenna where environmental conditions exceed those specified in Table B-5 on
page 54
G1 Environmental Considerations
The G1 is designed to withstand harsh environmental conditions; however, adhere to the following limits
when storing and using the G1:
• Operating temperature: -30°C to +70°C (-22°F to +158°F)
• Storage temperature: -40°C to +85°C (-40°F to +185°F)
• Humidity: 100% non-condensing
VHF Interference
VHF interference from such devices as cellular phones and radio transmitters may interfere with GPS
operation. Keep the following in mind regarding VHF interference:
• VHF marine radio working frequency (Channel 1 to 28) is from 156.05 to 157.40 MHz. The L1
GPS working center frequency is 1575.42 MHz. The bandwidth is +/- 2MHz to +/- 10 MHz, which
is dependent on the GPS antenna and receiver design.
• VHF marine radios emit strong harmonics. The 10th harmonic of VHF radio, in some channels,
falls into the GPS working frequency band, which may cause the SNR of GPS to degrade
significantly.
• The radiated harmonic signal strength of different brands/ models varies.
7
5
Page 10
Vector G1 User Guide
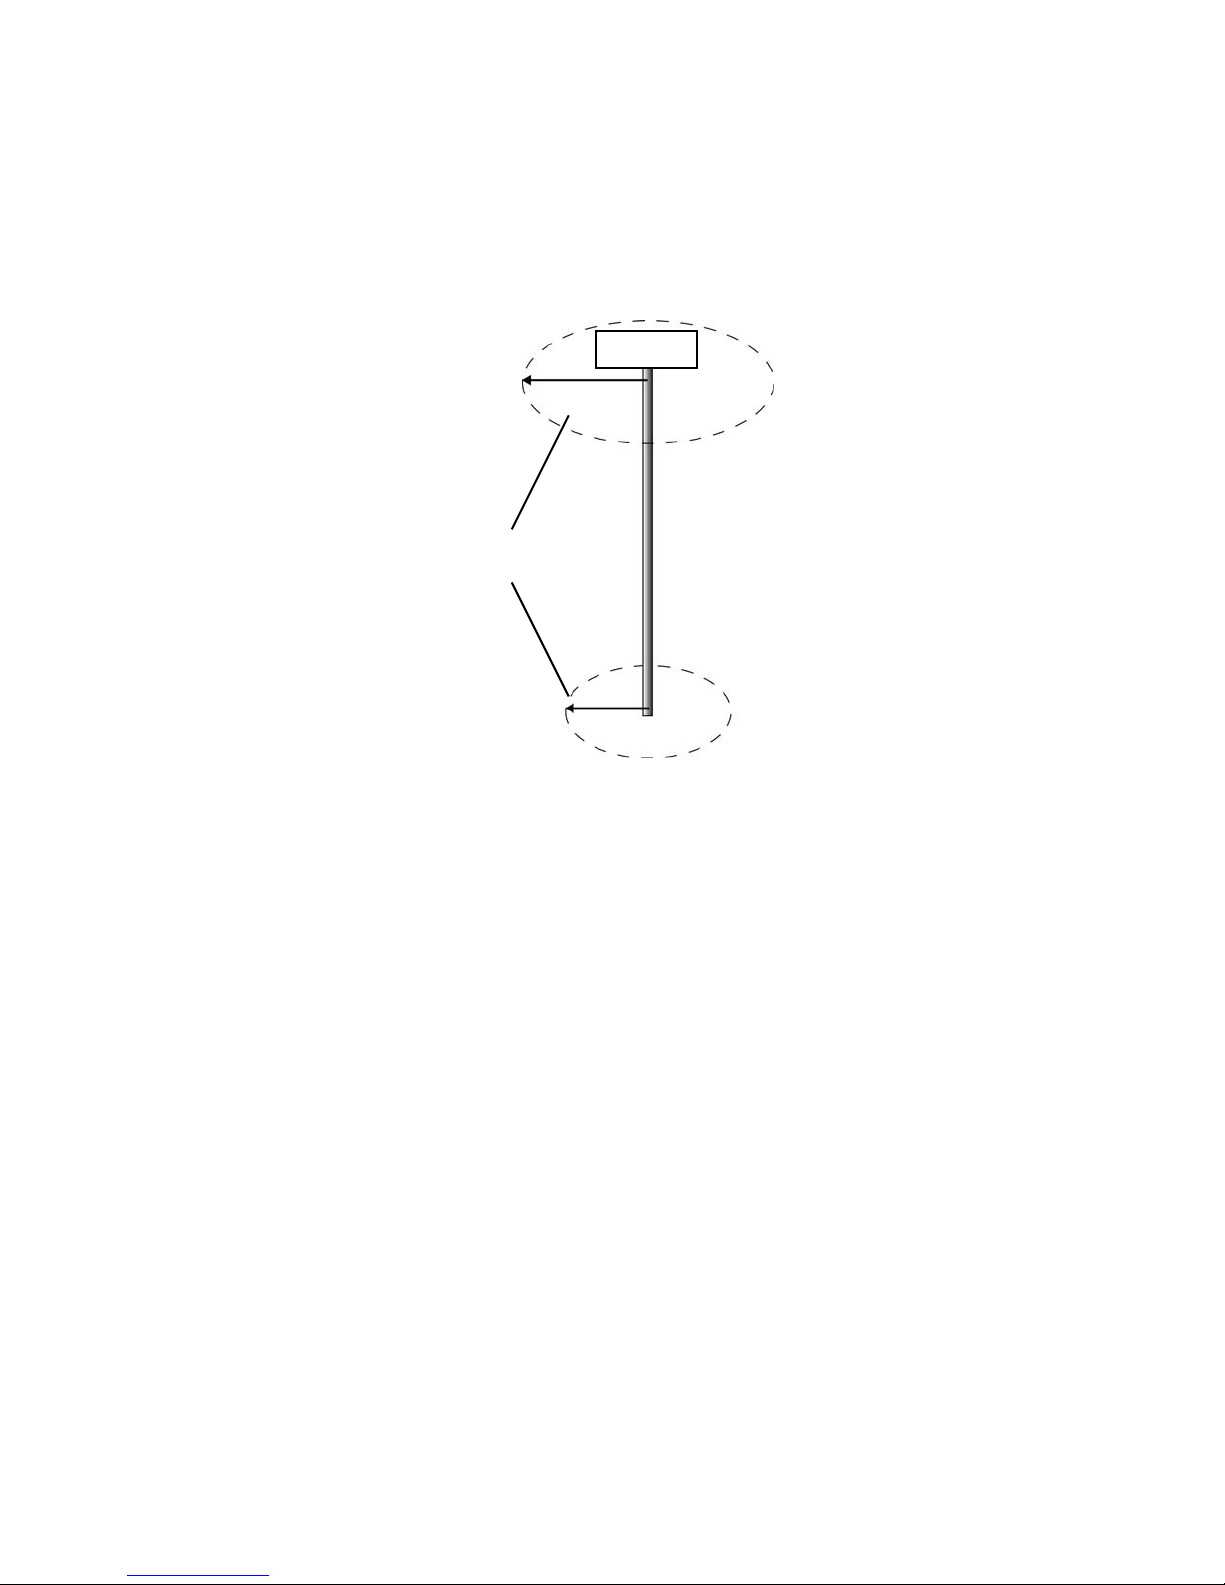
1.5 m radius at top
(minimum)
1.0 m radius at base
(minimum)
Use these minimum
distances to determine
where to place the G1
VHF Antenna
• Follow VHF radio manufacturers’ recommendations on how to mount their radios and what
devices to keep a safe distance away.
• Handheld 5W VHF radios may not provide suitable filtering.
Before installing the G1, use the following diagram to ensure there are no nearby devices that my cause
VHF interference.
Figure 2-1: G1 distance from nearby VHF radios
8
6
Page 11
Chapter 2: Installation
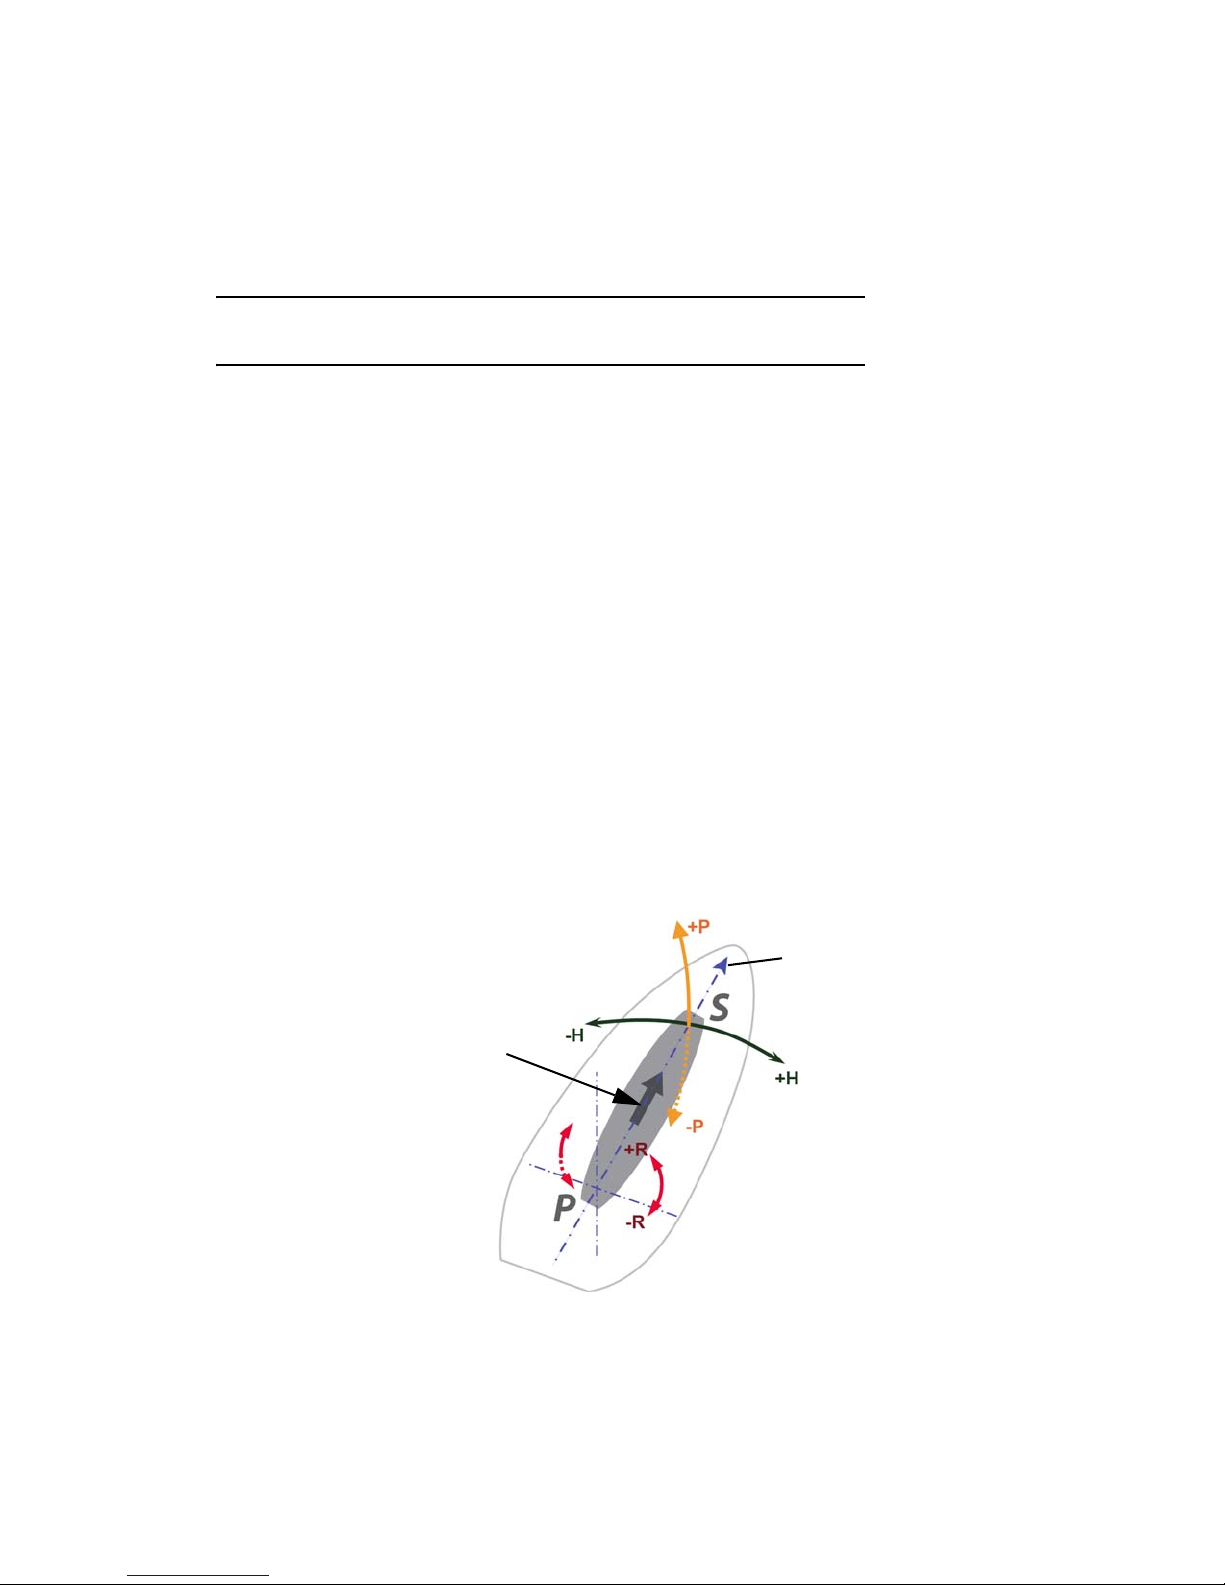
Forward
motion
Recessed arrow
located on
bottom of
enclosure
Mounting Orientation
The G1 outputs heading, pitch, and roll readings regardless of the orientation of the antennas. However, the
relation of the antennas to the boat’s axis determines whether you will need to enter a heading, pitch, or roll
bias. The primary antenna is used for positioning and the primary and secondary antennas, working in
conjunction, output heading, pitch, and roll values.
Note: Regardless of which mounting orientation you use, the G1 provides the ability to output the heave of
the vessel. This output is available via the $GPHEV message.
Parallel Orientation: The most common installation is to orient the G1 parallel to, and along the centerline
of, the axis of the boat. This provides a true heading. In this orientation:
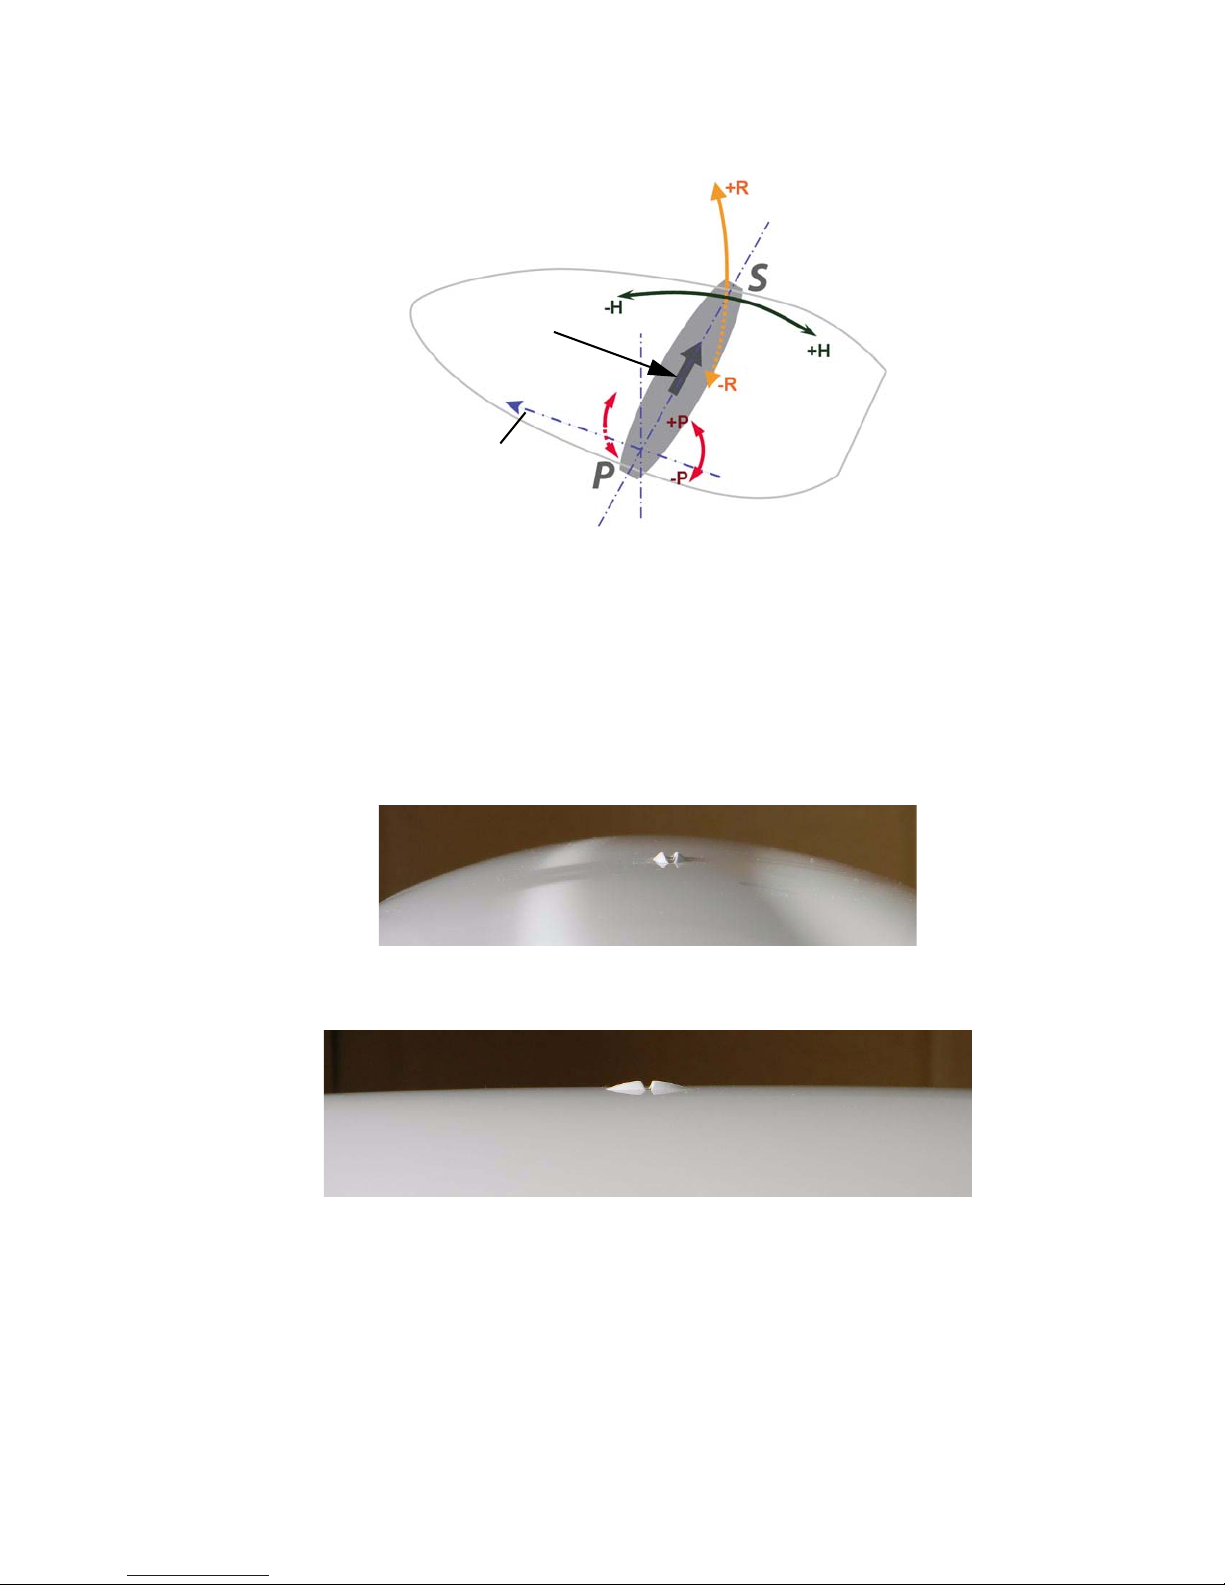
Perpendicular Orientation: You can also install the antennas so they are oriented perpendicular to the
centerline of the boat’s axis. In this orientation:
• If you use a gyrocompass, you can enter a heading bias in the G1 to calibrate the physical heading
to the true heading of the vessel.
• You may need to adjust the pitch/roll output to calibrate the measurement if the Vector is not
installed in a horizontal plane.
• You will need to enter a heading bias of +90° if the primary antenna is on the starboard side of the
boat and -90° if the primary antenna is on the port side of the boat.
• You will need to configure the receiver to specify the GPS antennas are measuring the roll axis
using $JATT,ROLL,YES.
• You will need to enter a roll bias to properly output the pitch and roll values.
• You may need to adjust the pitch/roll output to calibrate the measurement if the Vector is not
installed in a horizontal plane.
Figure 2-2 and Figure 2-3 provide mounting orientation examples
.
Figure 2-2: Recommended orientation and resulting signs of HPR values
9
7
Page 12
Vector G1 User Guide
Forward
motion
Recessed arrow
located on
bottom of
enclosure
Figure 2-3: Alternate orientation and resulting signs of HPR values
G1 Alignment
The top of the G1 enclosure incorporates sight design features to help you align the enclosure with respect to
an important feature on your vessel.
To use the sights, center the small post on the opposite side of the enclosure from you, within the channel
made in the medallion located in the center of the enclosure top as shown in Figure 2-4 and Figure 2-5.
Alignment accuracy when looking through the long site (Figure 2-4) is approximately +/- 1°, while
alignment through the short site (Figure 2-5) is approximately +/- 2.5°
If you have another accurate source of heading data on your vessel, such as a gyrocompass, you may use its
data to correct for a bias in G1 alignment within the G1 software configuration. Alternatively, you can
physically adjust the heading of the G1 so that it renders the correct heading measurement; however, adding
a software offset is an easier process
.
Figure 2-4: Long site alignment
Figure 2-5: Short sight alignment
.
10
8
Page 13
Chapter 2: Installation
C
L
C
L
66.90 mm
(2.63”)
SET SCREW
3/8-16 THREAD SIZE
2 PLACES
MOUNTING HOLE
1-14 UNS-2B THREAD SIZE
MOUNTING HOLE
1/4-20 UNC-2B THREAD SIZE
4 PLACES
416.93 mm (16.41”)
157.89 mm (6.21”)
46.99 mm
31.75 mm
(1.25”)
(1.85”)
Mounting Options
The G1 allows for two different mounting options: flush mount and pole mount.
G1 Dimensions
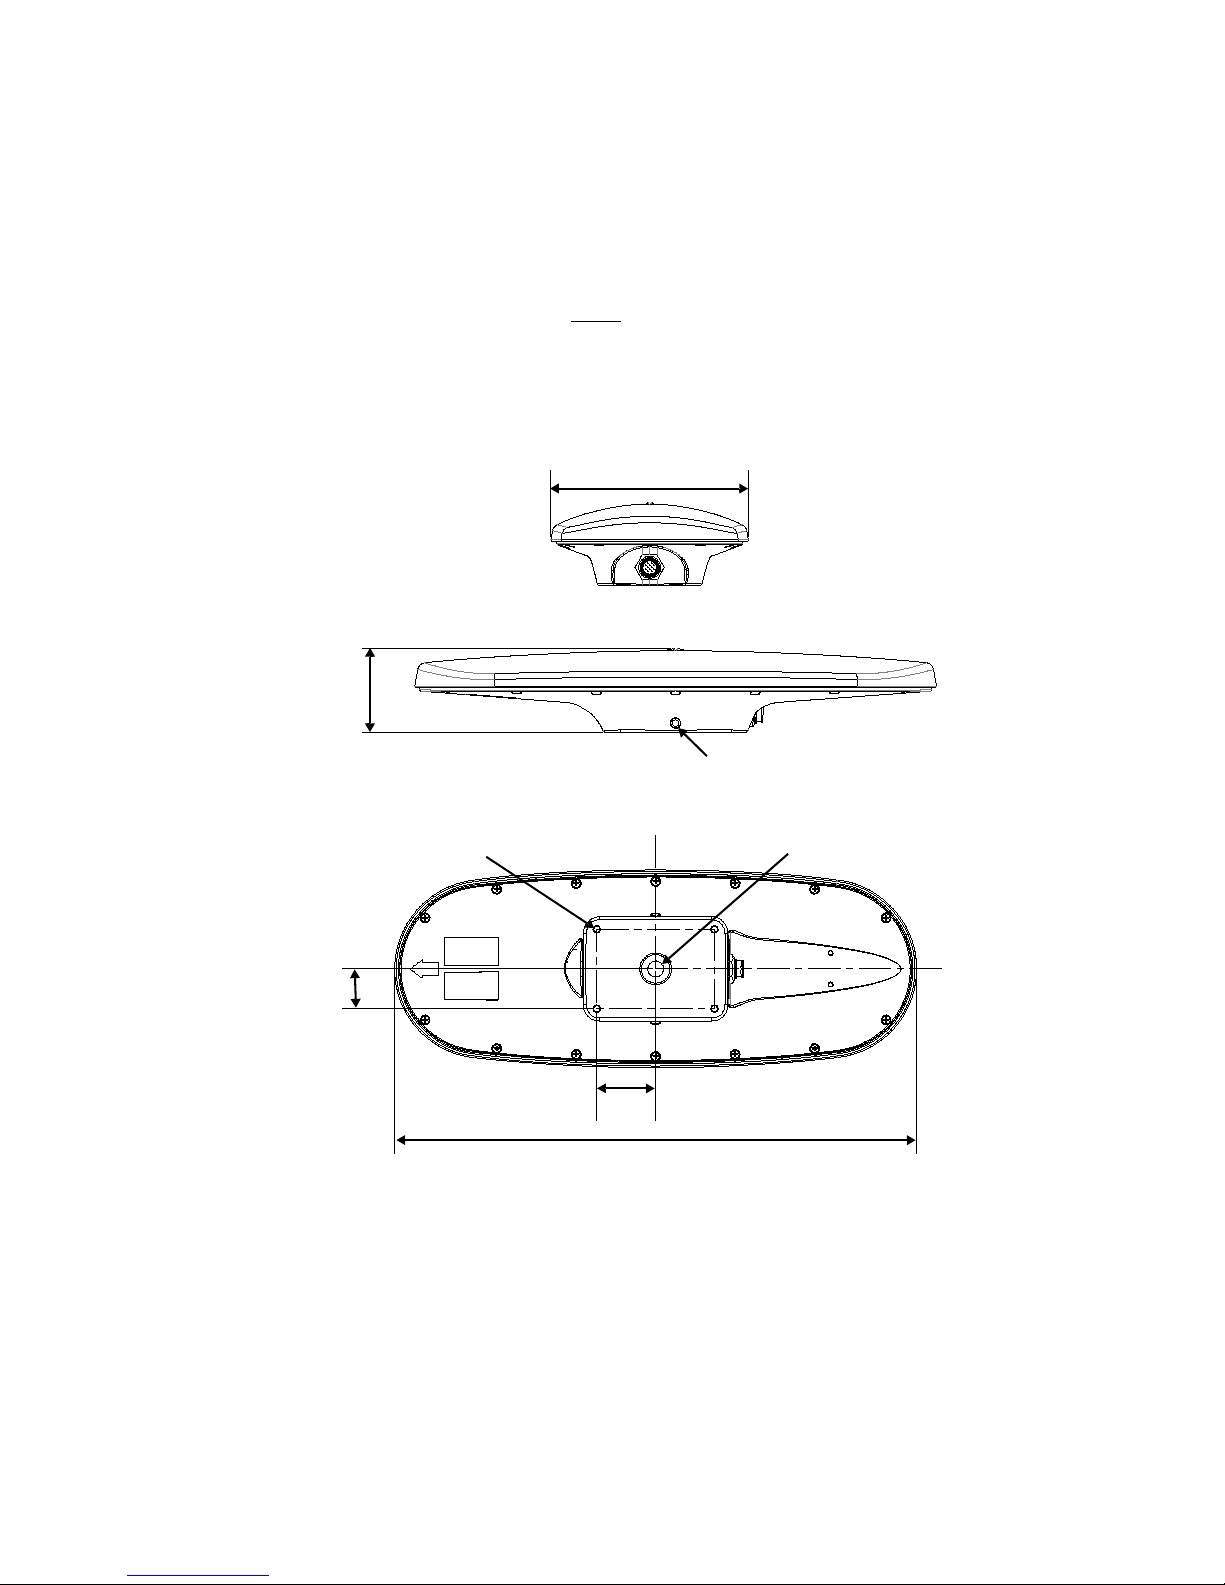
Figure 2-6 illustrates the physical dimensions of the G1
• Flush mount - The bottom of the G1 contains four M8 holes for flush mounting the unit to a flat
surface (see Figure 2-6).
• Pole mount - The bottom of the G1 contains a mounting hole (1" thread, 0.9" depth) for easy pole
mounting. Hand tighten until snug (do not
overtighten). The set screws on the long sides of the base
(see diagram below) allow you to secure the G1 in place (3/16" Allen wrench not included).
.
Figure 2-6: G1 dimensions
11
9
Page 14

Vector G1 User Guide
Power/Data Cable Considerations
Before mounting the G1 consider the following regarding power/data cable routing:
• Cable must reach an appropriate power source
• Cable may connect to a data storage device, computer, or other device that accepts GPS data
• Avoid running the cable in areas of excessive heat
• Keep cable away from corrosive chemicals
• Do not run the cable through door or window jams
• Keep cable away from rotating machinery
• Do not crimp or excessively bend the cable
• Avoid placing tension on the cable
• Remove unwanted slack from the cable at the G1 end
• Secure along the cable route using plastic wraps
Improperly installed cable near machinery can be dangerous
Flush Mount
The bottom of the G1 contains four holes for flush mounting the unit to a flat surface (Figure 2-7). The flat
surface may be something you fabricate per your installation, an off-the-shelf item (such as a radar mounting
plate), or an existing surface on your vessel.
Note: ComNav does not supply the mounting surface hardware. You must supply the appropriate fastening
hardware required to complete the installation of the G1.
Figure 2-7: Flush mounting holes on bottom of G1
Note: You do not necessarily need to orient the antenna precisely as you can enter a software offset to
accommodate for any bias in heading measurement due to installation.
Before flush mounting the G1:
• Determine your mounting orientation. See “Mounting Orientation” on page 7 for more
information.
10
12
Page 15
Chapter 2: Installation
Flush mounting the G1:
• Choose a location that meets the mounting location requirements.
• Using the fixed base as a template, mark and drill the mounting holes as necessary for the mounting
surface.
1. Photocopy the section of the G1 that contains the four mounting holes for use as a template to plan
the mounting hole locations.
Make sure the photocopy is scaled one to one with the mounting holes on the bottom
of the G1.
2. Mark the mounting hole centers on the mounting surface.
3. Place the G1 over the marks to ensure the planned hole centers align with the true hole centers
(adjusting as necessary).
4. Use a center punch to mark the hole centers.
5. Drill the mounting holes with a 9 mm bit appropriate for the surface.
6. Place the G1 over the mounting holes and insert the mounting screws through the bottom of the
mounting surface and into the G1.
When installing the G1, hand tighten only. Damage resulting from overtightening is
not covered by the warranty.
Pole Mount
Keep the following in mind when using a pole mount:
• Mounting hole is 1" thread, 0.9" depth
• Hand tighten until snug (do not
overtighten) while ensuring correct orientation
• Use the set screws on the long sides of the base (see Figure 2-6) to secure the G1 in place (3/16"
Allen wrench not included)
Overtightening may damage the system. This is not covered under warranty.
Before pole mounting the G1:
• Decide if you need the roll measurement. If you need roll measurement, the G1 will need to be
installed perpendicular to the vessel axis. If it you do not need roll measurement, install the G1
parallel with the vessel’s axis.
• Choose a location that meets the mounting location requirements.
13
11
Page 16
Vector G1 User Guide
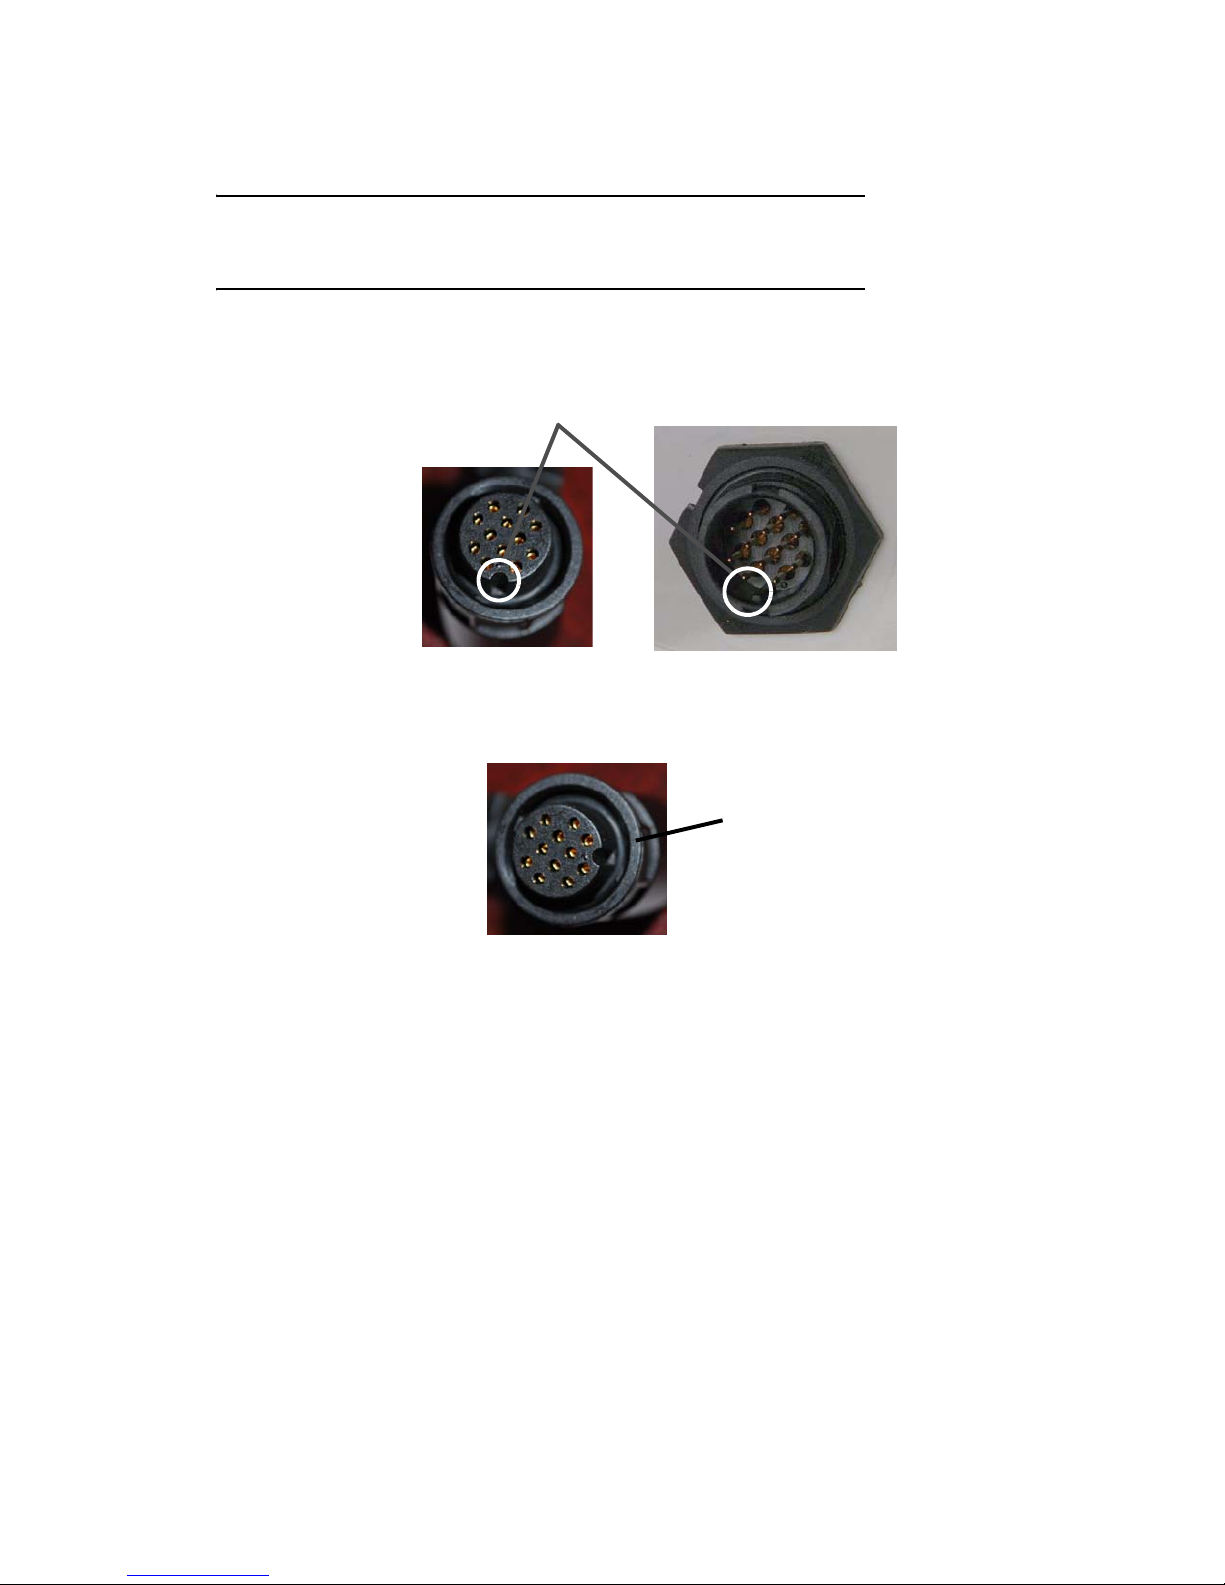
Make sure the connector keyway
on the cable matches up with the
connector key on the G1
Cable connector keyway G1 connector key
Cable ring
Connecting the power/data cable:
Note: This procedure is for connecting the serial 12-pin power/data cable to the G1. To connect the
serial-to-NMEA 2000 adapter to the G1, connect in a similar manner. See “NMEA 2000 Port” on page 14
for more information on the adapter.
1. Align the cable connector keyway with the G1 connector key.
Rotate the cable ring clockwise until it locks. The locking action is firm, but you will feel a positive
2.
“click” when it has locked
.
12
14
Page 17
Chapter 2: Installation
Ports
The G1 offers either serial port or NMEA 2000 port functionality.
Serial Ports
The G1 offers position and heading data via two full-duplex (bi-directional) RS-232 serial ports. In addition
to outputting data, these ports are used for firmware upgrades.
Selecting Baud Rates and Message Types
When selecting your baud rate and message types, use the following calculation to determine your baud rate
for your required data throughput.
Configuring the Ports
You may configure Port A or Port C of the GPS receiver to output any combination of data that you want.
Port A can have a different configuration from Port C in terms of data message output, data rates, and the
baud rate of the port. This allows you to configure the ports independently based upon your needs.
Messages * Message output rate * Message length (bytes) * bits in byte
Ex: 5 * 20Hz * 40 bytes * 10 = 40,000 bits/sec
The CAN processor that controls Port C is by default programmed into NMEA 2000 mode. You must
configure Port C as a serial port to use the G1 with two serial ports. Port A is always a serial port. To
configure Port C as a serial port refer to Table 2-1 on page 14.
For example, if you want one generalized port and one heading-only port, you can configure the ports as
follows:
• Port A to have GPGGA, GPVTG, GPGSV, GPZDA, and GPHDT all output at 1 Hz over a 9600
baud rate
• Port C to have GPHDT and GPROT output at their maximum rate of 20 Hz over a 19200 baud rate
A personal computer (PC) typically uses a DB9-male connector for RS-232 serial port communications.
Note: For successful communications use the 8-N-1 protocol and set the baud rate of the G1’s serial ports to
match that of the devices to which they are connected. Flow control is not supported.
Recommendations for Connecting to Other Devices
When interfacing to other devices, ensure the transmit data output from the G1 is connected to the data input
of the other device. The signal grounds must also be connected.
The G1 input ports are designed to work with the Navigator G2 compass display or PC PocketMax for
configuration purpose. There is likely little reason to connect the receive data input of the G1 to another
device. Unused input line can be left open.
Detailed wiring diagram for connections to ComNav autopilots and GPS display units are given in
Appendix D.
13
15
Page 18
Vector G1 User Guide
NMEA 2000 Port
By default, Port C is configured as a NMEA 2000 port with the default baud rate of 57600.
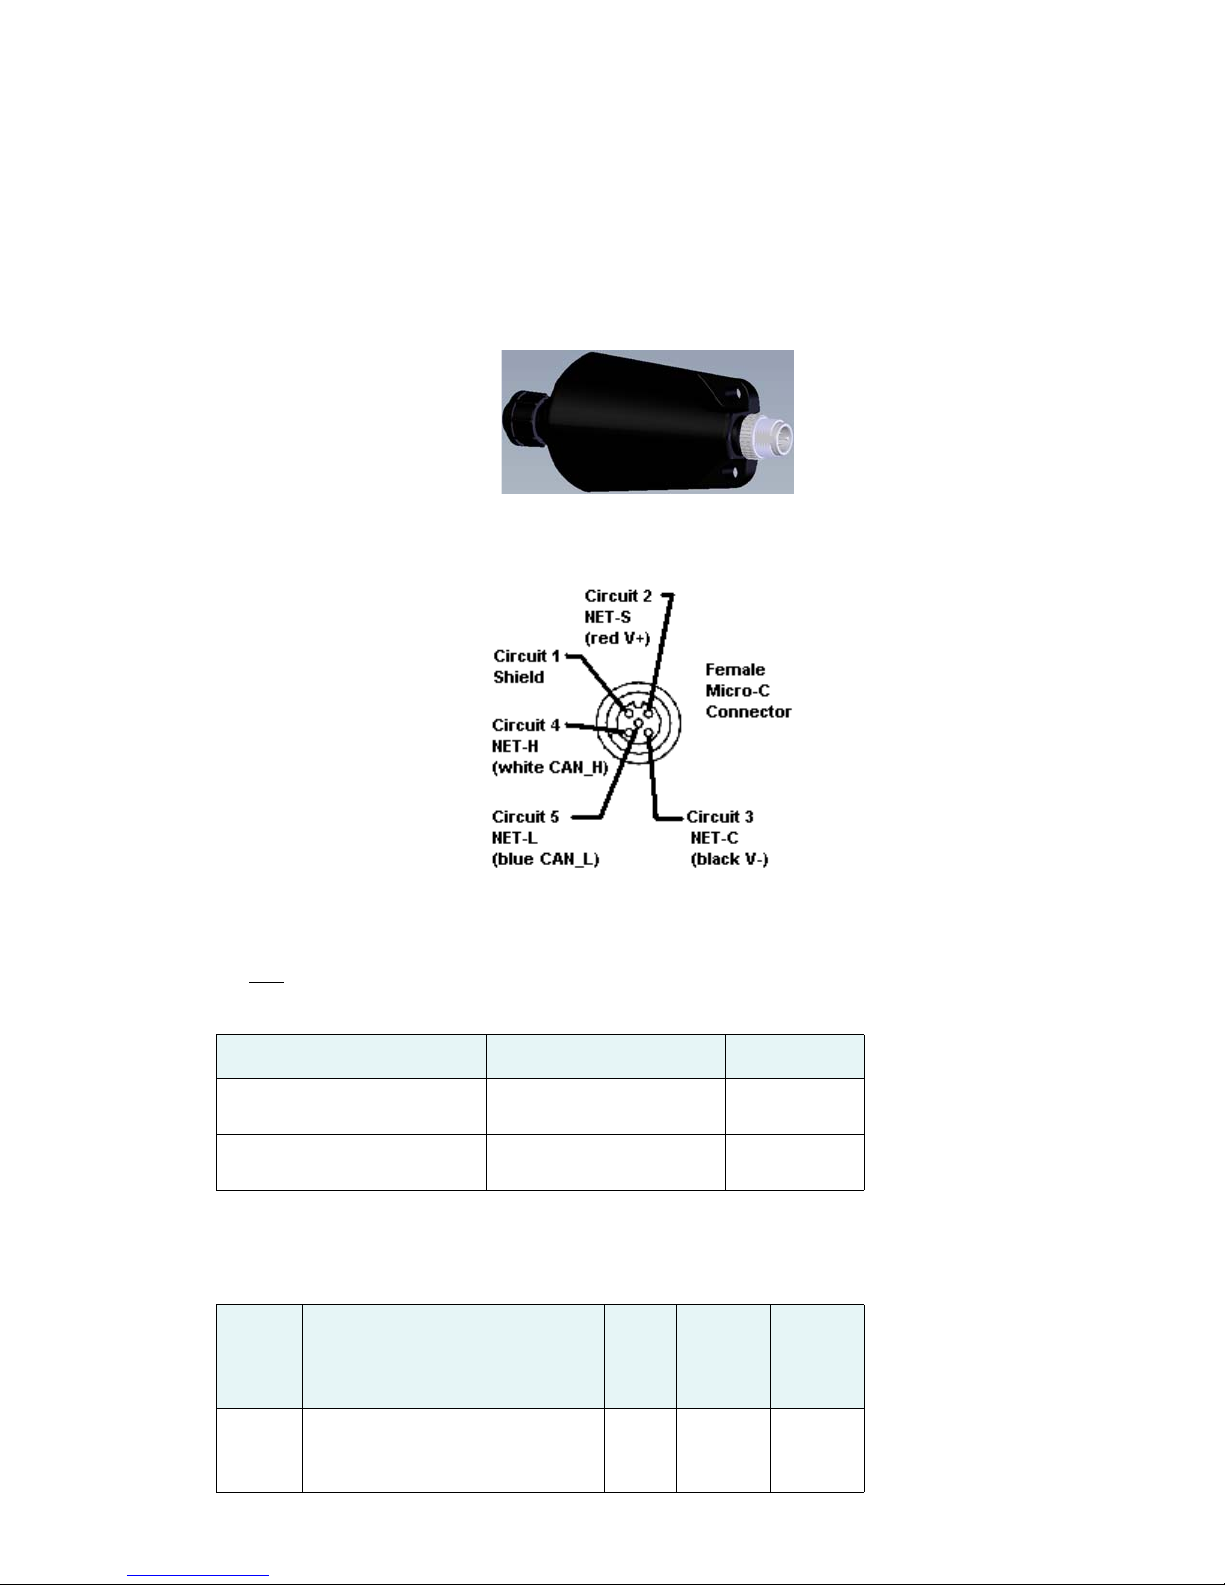
To use G1 for NMEA 2000 you have to connect the included serial-to-NMEA 2000 adapter (P/N 676-0026-000#) to the
unit. Figure 2-8 shows the adapter. Insert the 12-pin connector of the adapter into the male end of the 12-pin connector
on the G1 by aligning the keys. You can then attach the adapter to the unit using the supplied screws (machine, 8-32, ½”,
PPHC, SS) and washer (washer, flat, #8, SS). The 5-pin male Micro-C connector connects to your NMEA 2000 drop
cable.
Figure 2-8: Serial-to-NMEA 2000 adapter
NMEA 2000 Standard pinout
Table 2-1 lists the commands used to configure Port C back to serial or NMEA 2000 when necessary. You
can only
Table 2-1: Commands for changing Port C (must be sent through Port A)
send these commands using Port A.
Command Reply Description
$JRELAY,PORTC,$JSERIALMODE $>JSERIALMODE,ENABLED
$>resetting
$JRELAY,PORTC,$JN2KMODE $>JN2KMODE,ENABLED
$>resetting
Switch Port C to
serial
Switch Port C to
NMEA 2000
Table 2-2 shows the requested PGNs with the G1 in NMEA 2000 mode.
Table 2-2: Received messages based on a request
Default
PG No.
(PGN)
059392 ISO Acknowledgement
Description Level
Used to acknowledge the status of certain
requests addressed to a specific ECU.
B On Request On Request
Update
Rate
(msec)
Freq (Hz)
14
16
Page 19
Chapter 2: Installation
Table 2-2: Received messages based on a request (continued)
PG No.
(PGN)
Description Level
Default
Update
Rate
(msec)
Freq (Hz)
059904 ISO Request
Request the transmission of a specific PGN,
addressed or broadcast.
060928 ISO Address Claim
Used to identify to other ECUs the address
claimed by an ECU.
126996 Product Information
NMEA 2000 database version supported,
manufacturer’s product code, NMEA 2000
certification level, Load Equivalency
number, and other product-specific
information.
126464 Receive/Transmit PGNs group function
The Transmit / Receive PGN List Group
type of function is defined by first field. The
message will be a Transmit or Receive PGN
List group function.
129538 GNSS Control Status
GNSS common satellite receiver parameter
status.
129545 GNSS RAIM Output
Used to provide the output from a GNSS
receiver's Receiver Autonomous Integrity
Monitoring (RAIM) process. The Integrity
field value is based on the parameters set in
PGN 129546 GNSS RAIM Settings.
B On Request On Request
B On Request On Request
B On Request On Request
B On Request On Request
B On Request On Request
B On Request On Request
129546 GNSS RAIM Settings
Used to report the control parameters for a
GNSS Receiver Autonomous Integrity
Monitoring (RAIM) process.
B On Request On Request
Table 2-3 shows the transmitted PGNs with their default update rate with the G1 in NMEA 2000 mode.
Table 2-3: Transmitted messages
Default
PG No.
(PGN)
126992 System Time
127250 Vessel Heading
Description Level
The purpose of this PGN is twofold: To provide a
regular transmission of UTC time and date. To
provide synchronism for measurement data.
Heading sensor value with a flag for True or
Magnetic. If the sensor value is Magnetic, the
deviation field can be used to produce a Magnetic
heading, and the variation field can be used to correct
the Magnetic heading to produce a True heading.
Update
Rate
(msec)
B
B
1000 1
100 10
Freq
(Hz)
15
17
Page 20
Table 2-3: Transmitted messages (continued)
PG No.
(PGN)
Description Level
Default
Update
Rate
(msec)
Vector G1 User Guide
Freq
(Hz)
127251 Rate of Turn
Rate of change of the Heading.
127257 Attitude
Provides a single transmission that describes the
position of a vessel relative to both horizontal and
vertical planes. This would typically be used for
vessel stabilization, vessel control and onboard
platform stabilization.
127258 Magnetic Variation
Message for transmitting variation. The message
contains a sequence number to allow synchronization
of other messages such as Heading or Course over
Ground. The quality of service and age of service are
provided to enable recipients to determine an
appropriate level of service if multiple transmissions
exist.
128259 Speed
Provides a single transmission that describes the
motion of a vessel.
129025 Position, Rapid Update
Provides latitude and longitude referenced to
WGS84. Being defined as single frame message, as
opposed to other PGNs that include latitude and
longitude and are defined as fast or multi-packet, this
PGN lends itself to being transmitted more
frequently without using up excessive bandwidth on
the bus for the benefit of receiving equipment that
may require rapid position updates.
B
B
B
B
100 10
1000 1
1000 1
1000 1
100 10
129026 COG & SOG, Rapid Update
Single frame PGN that provides Course Over
Ground (COG) and Speed Over Ground (SOG).
129027 Position Delta, High Precision Rapid Update
The "Position Delta, High Precision Rapid Update"
Parameter Group is intended for applications where
very high precision and very fast update rates are
needed for position data. This PGN can provide delta
position changes down to 1 mm with a delta time
period accurate to 5 msec.
129028 Altitude Delta, High Precision Rapid Update
The "Altitude Delta, High Precision Rapid Update"
Parameter Group is intended for applications where
very high precision and very fast update rates are
needed for altitude and course over ground data. This
PG can provide delta altitude changes down to 1
millimeter, a change in direction as small as 0.0057°,
and with a delta time period accurate to 5 msec.
129029 GNSS Position Data
Conveys a comprehensive set of Global Navigation
Satellite System (GNSS) parameters, including
position information.
16
18
B
B
B
B
250 4
100 10
100 10
1000 1
Page 21
Chapter 2: Installation
Table 2-3: Transmitted messages (continued)
PG No.
(PGN)
Description Level
Default
Update
Rate
(msec)
Freq
(Hz)
129033 Time & Date
Single transmission that provides UTC time, UTC
Date, and Local Offset.
129539 GNSS DOPs
Provides a single transmission containing GNSS
status and dilution of precision components (DOP)
that indicate the contribution of satellite geometry to
the overall positioning error. There are three DOP
parameters reported: horizontal (HDOP), Vertical
(VDOP), and time (TDOP).
129540 GNSS Sats in View
GNSS information on current satellites in view
tagged by sequence ID. Information includes PRN,
elevation, azimuth, SNR, defines the number of
satellites; defines the satellite number and the
information.
B
B
B
1000 1
1000 1
1000 1
17
19
Page 22
Vector G1 User Guide
J1 P1
30 mm
Strip and tin 3 mm
25 mm
100 mm
15 m
Powering the G1
Power Considerations
For best performance use a clean and continuous power supply. The G1 power supply features reverse
polarity protection but will not operate with reverse polarity.
See Table B-3 on page 53 for complete power specifications.
Connecting to a Power Source
Note: This section refers to powering the unit via serial connection. To power the unit via NMEA 2000
connection, following the standard procedure for powering up via NMEA 2000.
Before you power up the G1 you must terminate the wires of the power cable as required. There are a variety
of power connectors and terminals on the market from which to choose, depending on your specific
requirements.
Do not apply a voltage higher than 36 VDC. This will damage the receiver and void the
warranty.
To interface the G1 power cable to the power source:
• Connect the red wire of the cable’s power input to DC positive (+)
• Connect the black wire of the cable’s power input to DC negative (-)
The G1’s smart antenna will start when an acceptable voltage is applied to the power leads of the extension
cable.
Electrical Isolation
The G1’s power supply is isolated from the communication lines and the PC-ABS plastic enclosure isolates
the electronics mechanically from the vessel (addressing the issue of vessel hull electrolysis).
Connecting the G1 to External Devices
Note: This section refers to a serial connection. For connecting external NMEA 2000 devices, plug the
serial-to-NMEA 2000 adapter into the G1 and then attach a standard NMEA 2000 dropline cable to the
adapter.
Power/Data Cable Considerations
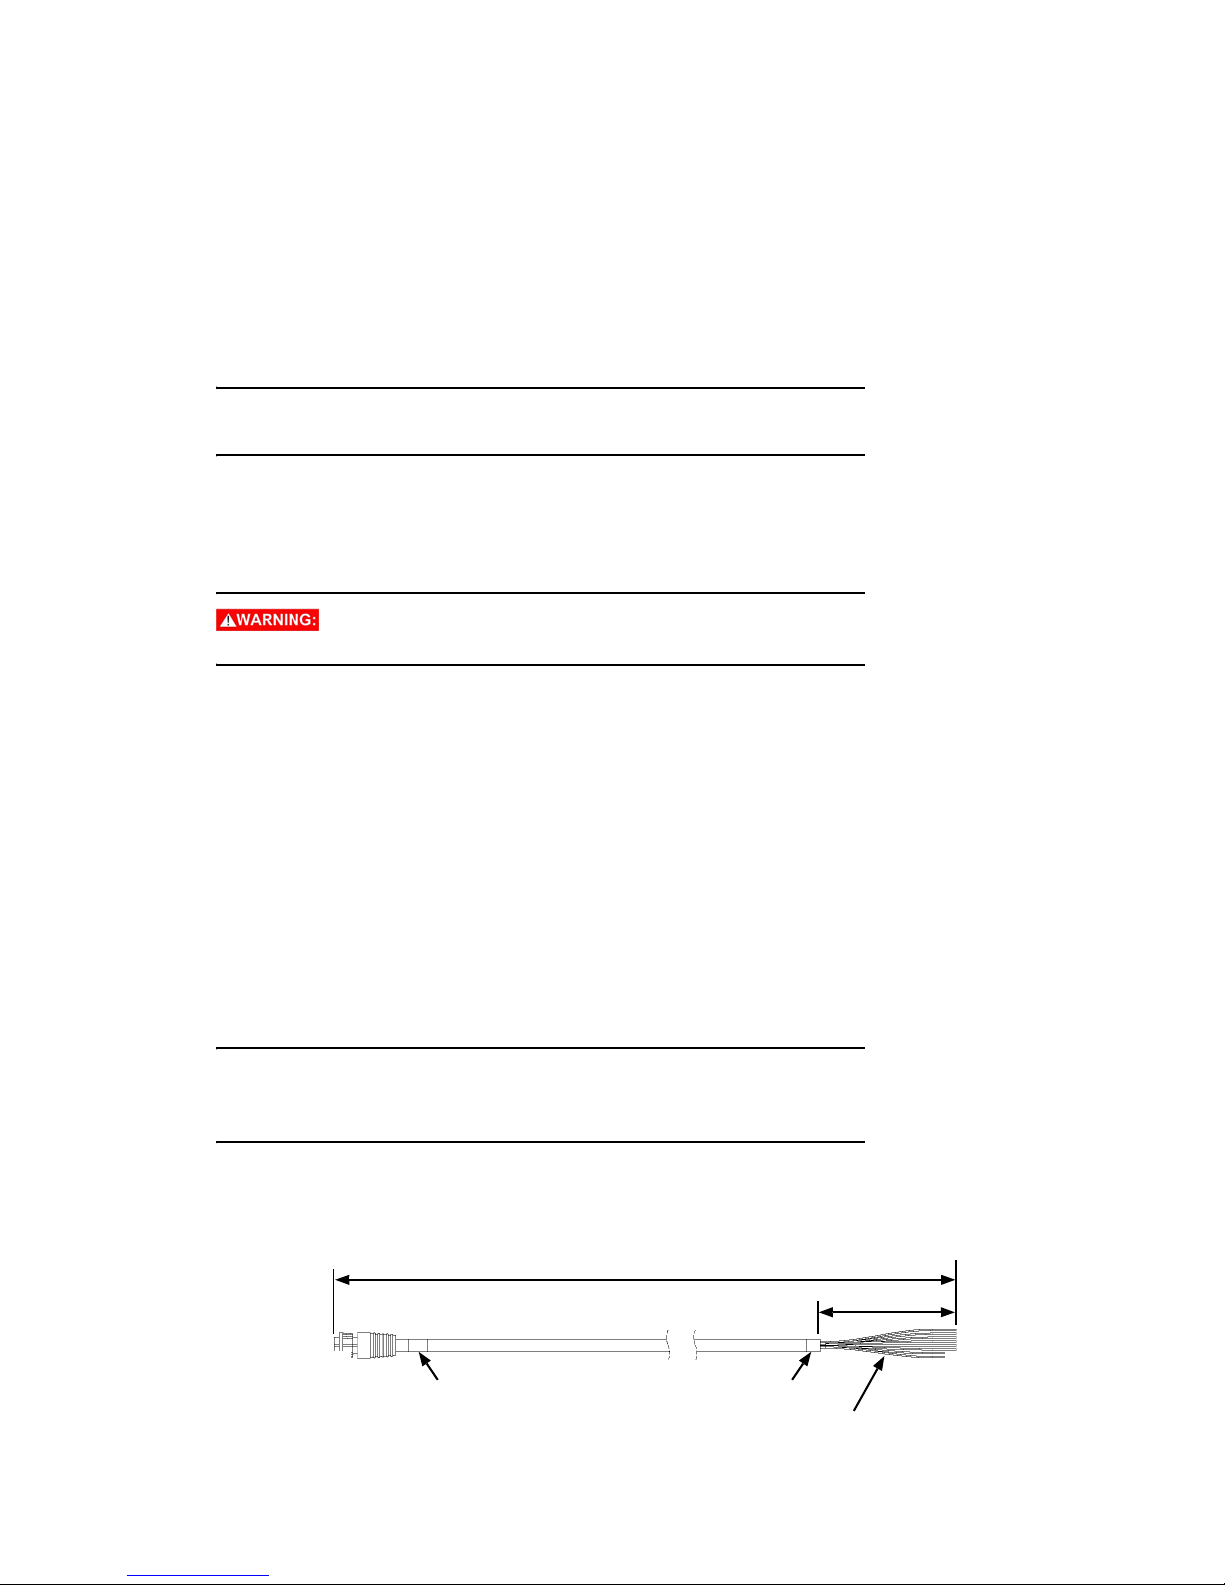
The G1 uses a single 15 m (49 ft) cable for power and data input/output.
Figure 2-9: Power/data cable, 15 m
18
20
Page 23
Chapter 2: Installation
The receiver end of the cable is terminated with an environmentally sealed 12-pin connection while the
opposite end is unterminated and requires field stripping and tinning.
Depending on the application and installation needs, you may need to shorten this cable. However, if you
require a longer cable run than 15 m, you can bring the cable into a break-out box that incorporates terminal
strips, within the vessel.
When lengthening the cable keep the following in mind:
Power/Data Cable Pinout Specifications
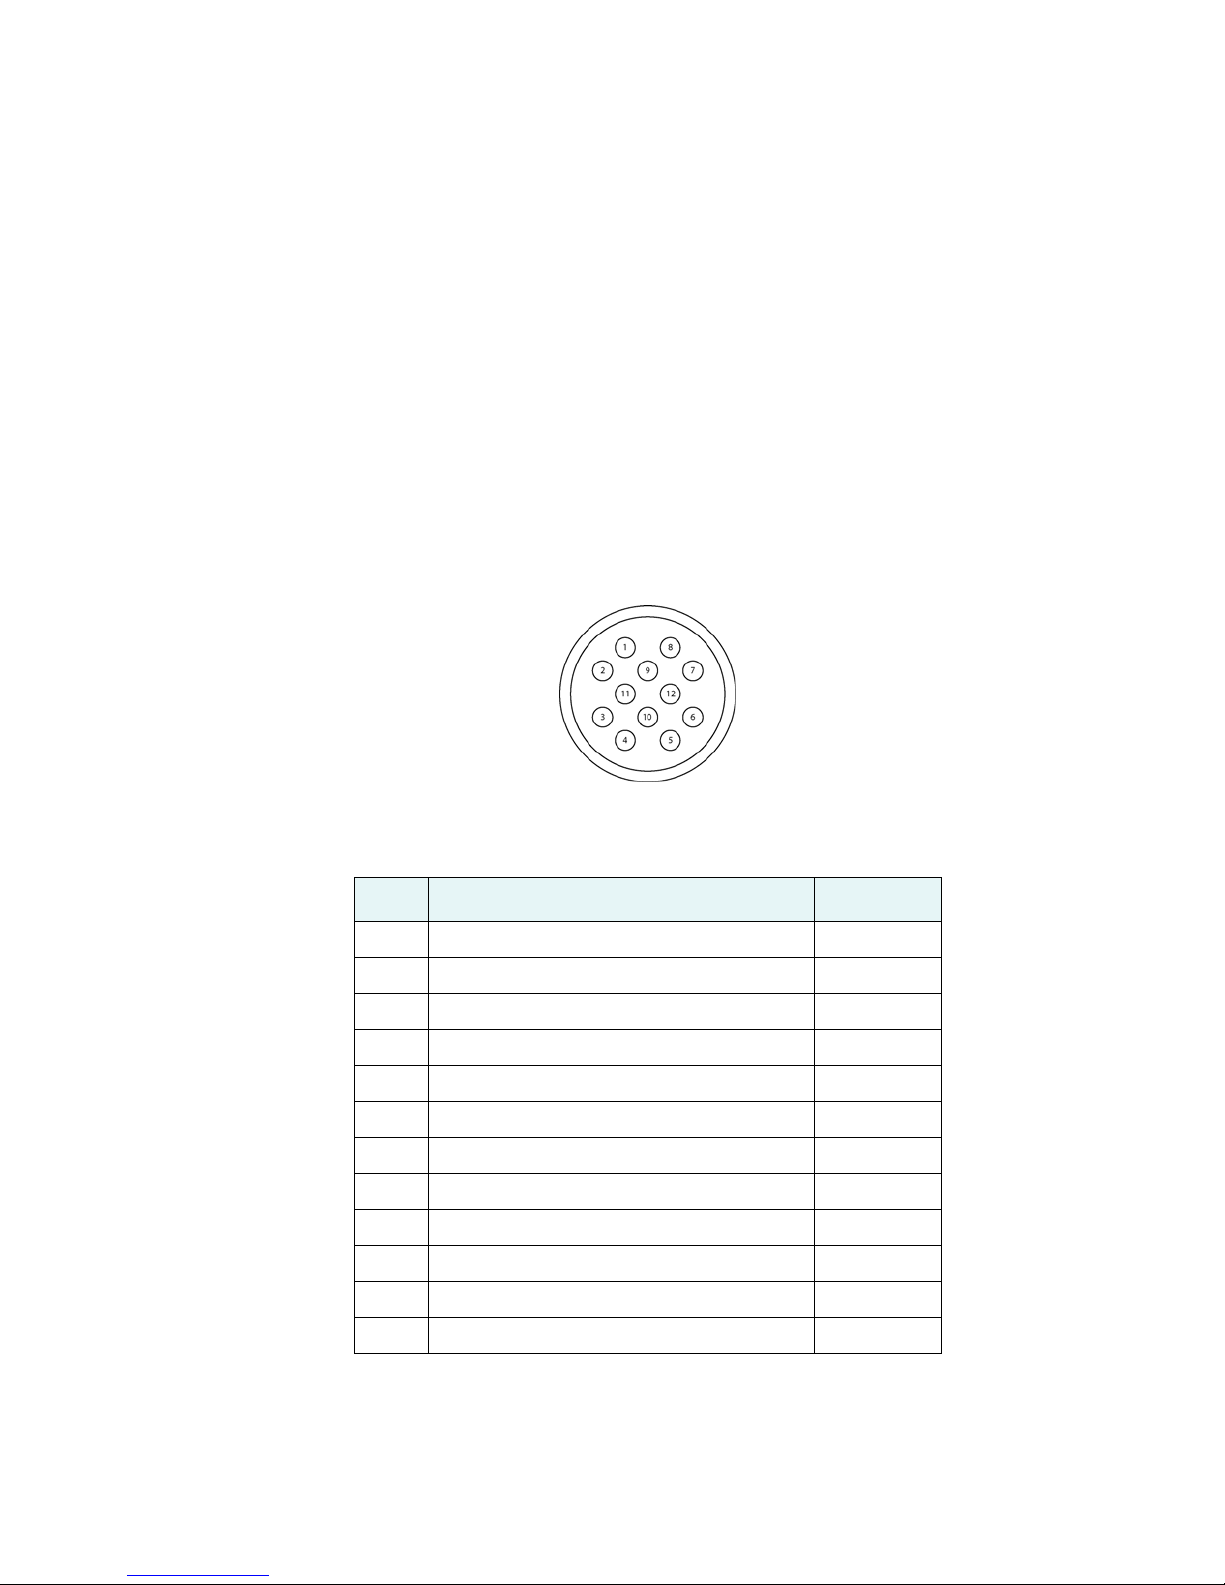
Figure 2-10 show the power/data cable plug pinout while Table 2-4 shows the cable’s pinout specifications
• To lengthen the serial lines inside the vessel, use 20-gauge twisted pairs and minimize the
additional wire length.
• When lengthening the power input leads to the G1, ensure the additional voltage drop is small
enough that your power system can continue to power the system above the minimum voltage of
the system. Wire of 18-gauge or larger should also be used.
• Length limits for RS-232 cables
.
Figure 2-10: Power/data cable pin assignment
Table 2-4: Power/data cable pinout
Pin Function Wire Color
1 Port C, RS-232 female DB9 pin 2, device out (Tx) White
2 Port C, RS-232 female DB9 pin 3, device in (Rx) Green
3 N/C N/C
4 N/C N/C
5 Power input Red
6 N/C N/C
7 Signal ground Yellow
8 Port A, RS-232 female DB9 pin 3, device in (Rx) Brown
9 Port A, RS-232 female DB9 pin 2, device out (Tx) Blue
10 Power ground Black
11 CH_GND Drain
12 N/C N/C
19
21
Page 24
22
Page 25
Chapter 3: Operation
GPS Overview
Vector G1 Overview
Messages and Configuration Commands
20
23
Page 26
24
Page 27
Vector G1 User Guide
GPS Overview
For your convenience, both the GPS and SBAS operation of the Vector G1 features automatic operational
algorithms. When powered for the first time, the Vector G1 performs a "cold start," which involves
acquiring the available GPS satellites in view and the SBAS differential service.
If SBAS is not available in your area, an external source of RTCM SC-104 differential corrections may be
used. If you use an external source of correction data, it must support an eight data bit, no parity, one stop bit
configuration (8-N-1).
GPS Operation
The GPS receiver is always operating, regardless of the DGPS mode of operation. The following sections
describe the general operation of the G1’s internal GPS receiver.
Note: Differential source and status have no impact on heading, pitch, or roll. They only have an impact on
positioning.
Automatic Tracking
The G1’s internal GPS receiver automatically searches for GPS satellites, acquires the signals, and manages
the navigation information required for positioning and tracking.
Receiver Performance
The G1 works by finding four or more GPS satellites in the visible sky. It uses information from the
satellites to compute a position within 4.0 m (8.2 ft). Since there is some error in the GPS data calculations,
the G1 also tracks a differential correction. The G1 uses these corrections to improve its position accuracy to
better than 1.0 m (1.97 ft).
There are two main aspects of GPS receiver performance:
• Satellite acquisition
• Positioning and heading calculation
When the G1 is properly positioned, the satellites transmit coded information to the antennas on a specific
frequency. This allows the receiver to calculate a range to each satellite from both antennas. GPS is
essentially a timing system. The ranges are calculated by timing how long it takes for the signal to reach the
GPS antenna. The GPS receiver uses a complex algorithm incorporating satellite locations and ranges to
each satellite to calculate the geographic location and heading. Reception of any four or more GPS signals
allows the receiver to compute three-dimensional coordinates and a valid heading.
Differential Operation
The purpose of differential GPS (DGPS) is to remove the effects of selective availability (SA), atmospheric
errors, timing errors, and satellite orbit errors, while enhancing system integrity. Autonomous positioning
capabilities of the G1 will result in positioning accuracies of 4.0 m (8.2 ft) 95% of the time. In order to
improve positioning quality to better than 1.0 m (1.97 ft), the G1 is able to use differential corrections
received through the internal SBAS demodulator or externally-supplied RTCM corrections
.
Automatic SBAS Tracking
The G1 automatically scans and tracks SBAS signals without the need to tune the receiver. The G1 features
two-channel tracking that provides an enhanced ability to maintain a lock on an SBAS satellite when more
than one satellite is in view. This redundant tracking approach results in more consistent tracking of an
SBAS signal in areas where signal blockage of a satellite is possible.
22
125
Page 28
Chapter 3: Operation
0.27 m
Primary antenna
baseline
Vector G1 Overview
The G1 provides accurate and reliable heading and position information at high update rates. To accomplish
this task, the G1 uses a high performance GPS receiver and two antennas for GPS signal processing. One
antenna is designated as the primary GPS antenna and the other is the secondary GPS antenna. Positions
computed by the G1 are referenced to the phase center of the primary GPS antenna. Heading data references
the vector formed from the primary GPS antenna phase center to the secondary GPS antenna phase center.
The heading arrow located on the bottom of the G1 enclosure defines system orientation. The arrow points
in the direction the heading measurement is computed (when the antenna is installed parallel to the fore-aft
line of the vessel). The secondary antenna is directly above the arrow.
Fixed Baseline Moving Base Station RTK
The G1’s internal GPS receiver uses both the L1 GPS C/A code and carrier phase data to compute the
location of the secondary GPS antenna in relation to the primary GPS antenna with a very high
sub-centimeter level of precision. The technique of computing the location of the secondary GPS antenna
with respect to the primary antenna, when the primary antenna is moving, is often referred to as moving base
station Real Time Kinematic (or moving base station RTK).
Generally, RTK technology is very sophisticated and requires a significant number of possible solutions to
be analyzed where various combinations of integer numbers of L1 wavelengths to each satellite intersect
within a certain search volume. The integer number of wavelengths is often referred to as the “ambiguity” as
they are initially ambiguous at the start of the RTK solution.
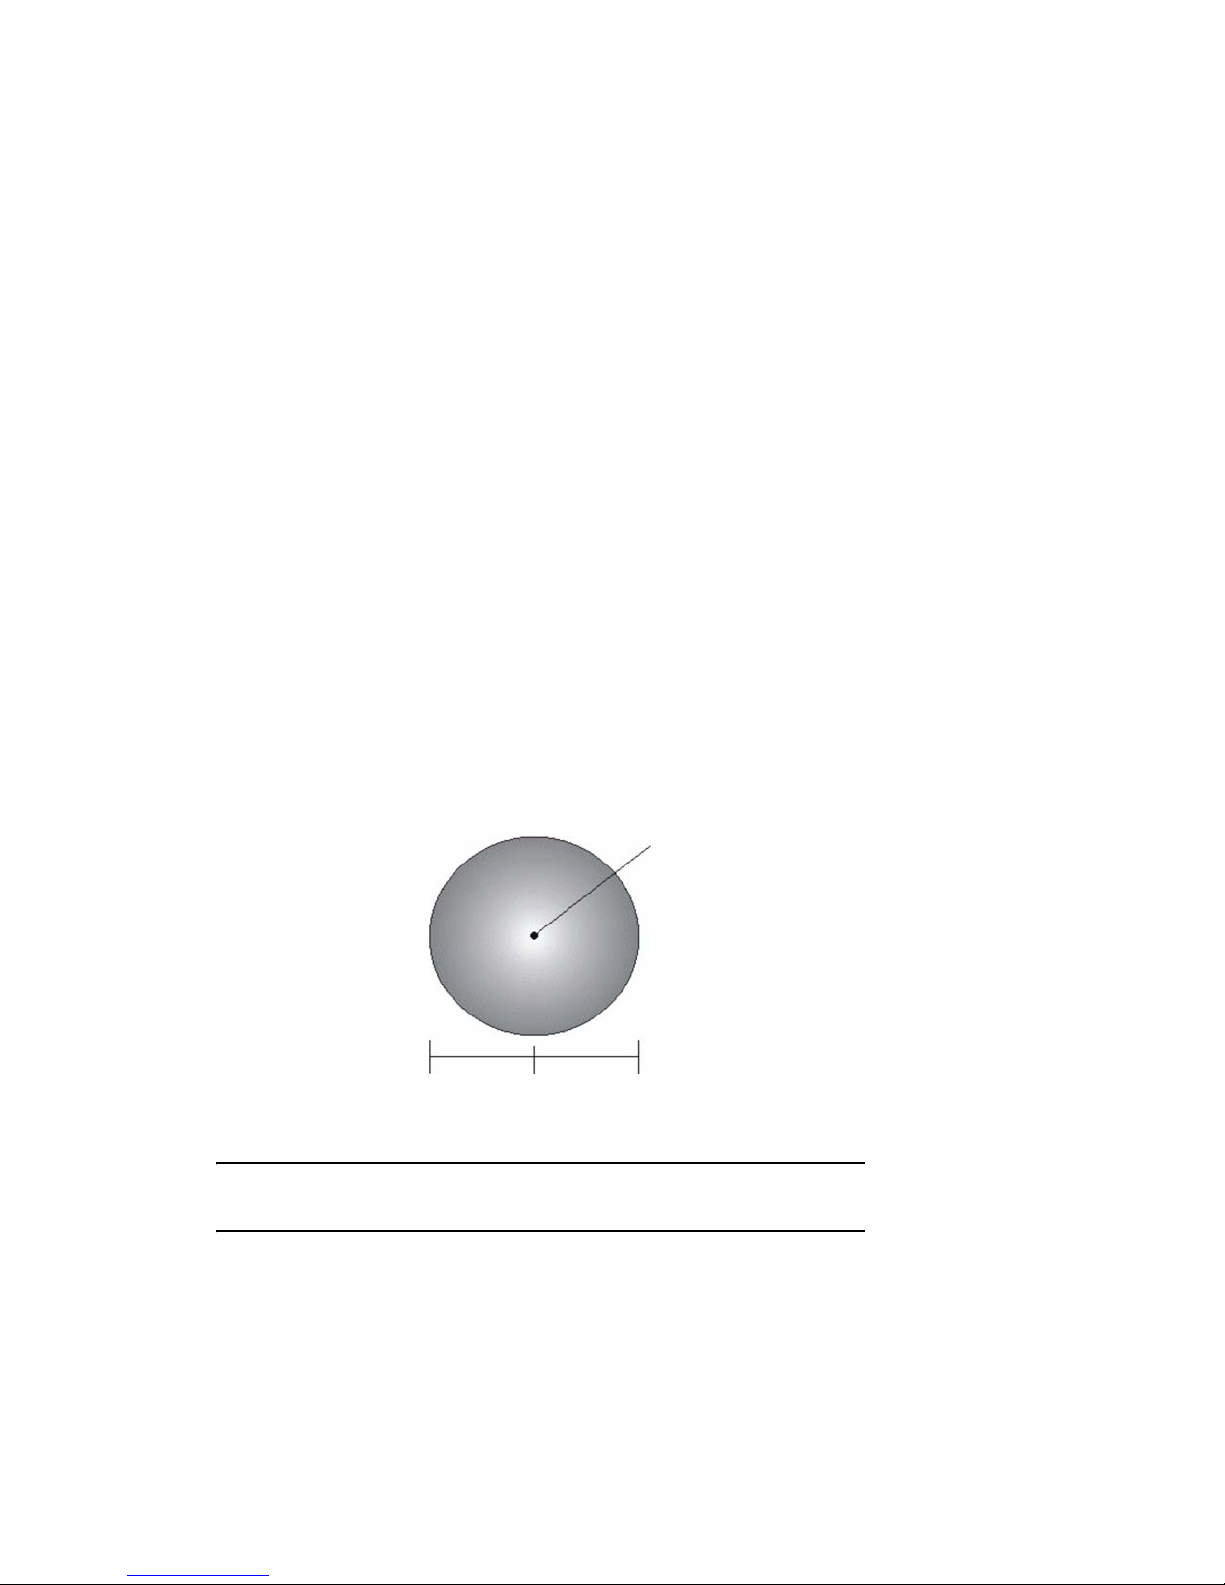
The G1 restricts the RTK solution. It does this knowing that the secondary GPS antenna is 0.27 m (0.89 ft)
from the primary GPS antenna. This is called a fixed baseline and it defines the search volume of the
secondary antenna as the surface of a sphere with radius 0.27 m (0.89 ft) centered on the location of the
primary antenna (see Figure 3-1)
.
Figure 3-1: Secondary antenna’s search volume
Note: The Vector G1 moving base station algorithm only uses GPS to calculate heading. Differential
corrections are not used in this calculation and will not affect heading accuracy.
Supplemental Sensors
The G1 has an integrated gyro and two tilt sensors. The gyro and tilt sensors are enabled by default. Each
supplemental sensor may be individually enabled or disabled. Both supplemental sensors are mounted on
the printed circuit board inside the G1.
The sensors act to reduce the RTK search volume, which improves heading startup and reacquisition times.
This improves the reliability and accuracy of selecting the correct heading solution by eliminating other
possible, erroneous solutions. Table 3-1 on page 24 provides a sensor operation summary
23
.
26
Page 29
Vector G1 User Guide
Tilt angle
Feature Normal Operation Coasting (no GPS)
Heading GPS Gyro
Heave GPS None
Pitch GPS Inertial sensor
Roll Inertial sensor Inertial sensor
Table 3-1: Sensor operation summary
Sensors can be recalibrated, queried, or disabled by some NMEA-like sentences. See descriptions in
Messages and Configuration Commands.
Tilt Aiding
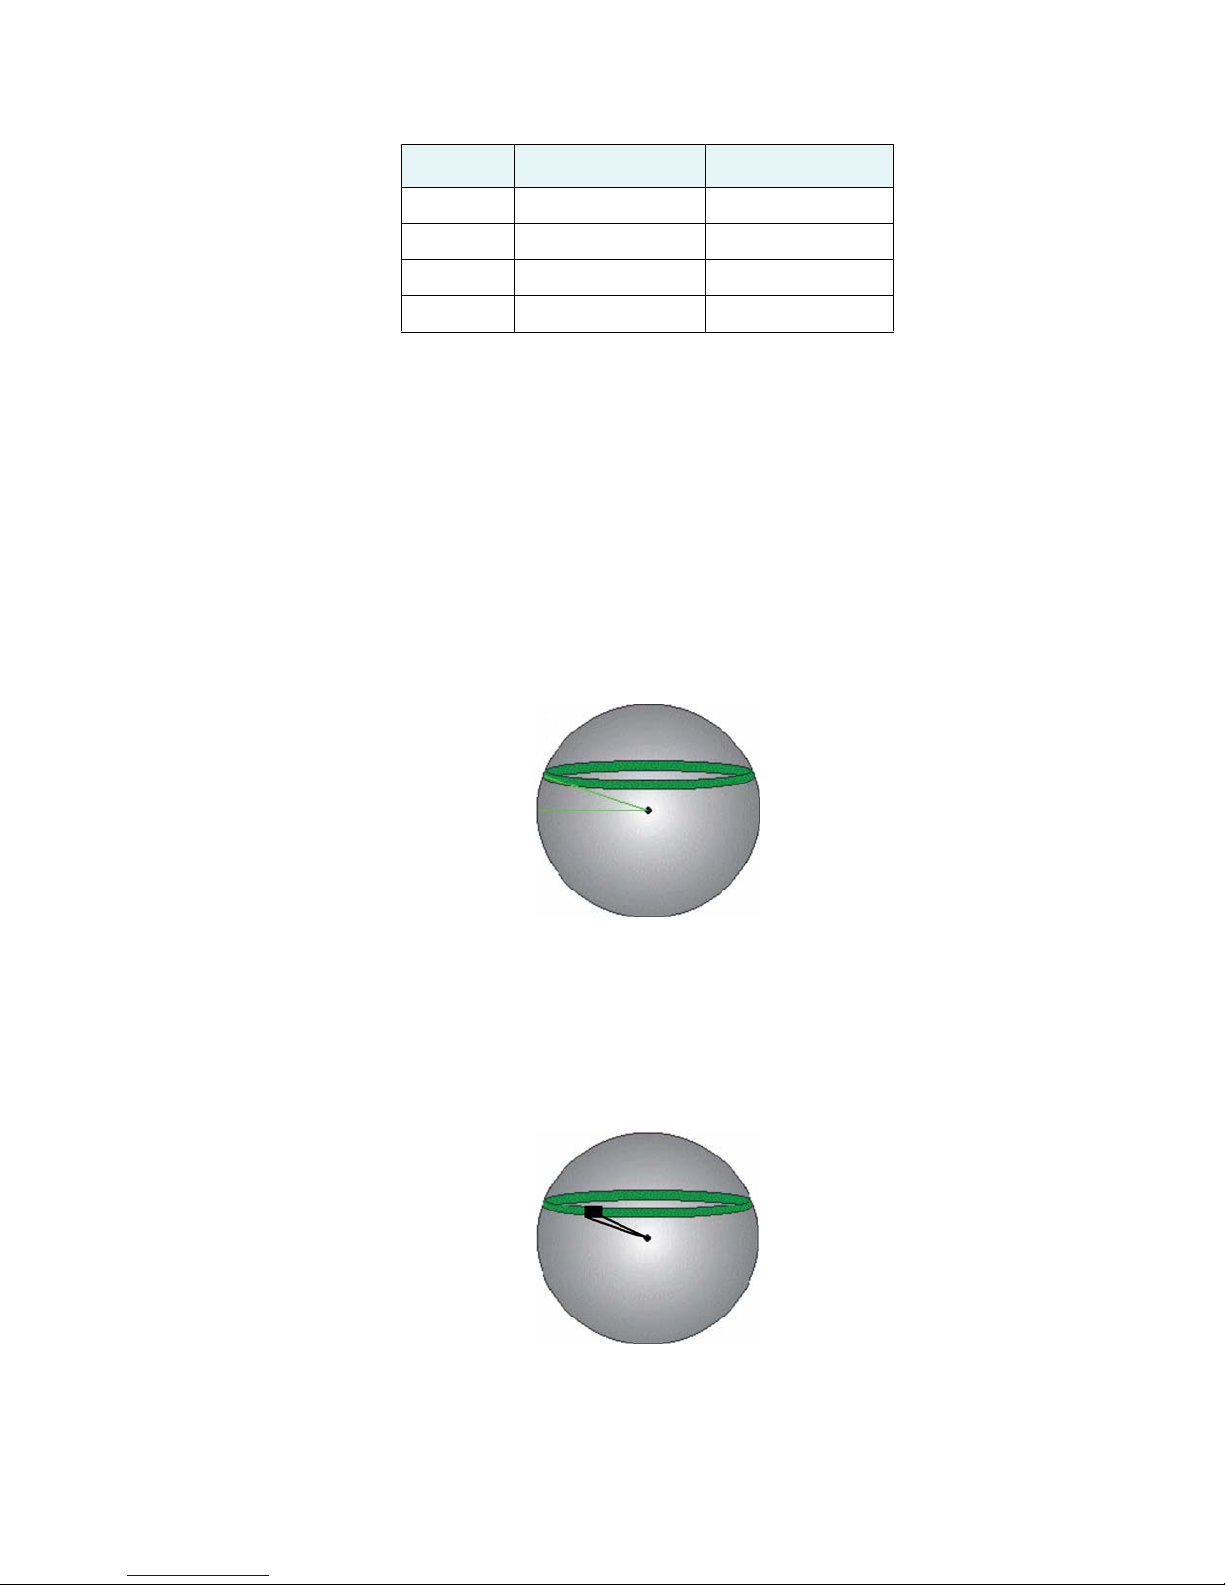
The G1’s accelerometers (internal tilt sensors) are factory calibrated and enabled by default. This constrains
the RTK heading solution beyond the volume associated with just a fixed antenna separation. This is
because the G1 knows the approximate inclination of the secondary antenna with respect to the primary
antenna. The search space defined by the tilt sensor will be reduced to a horizontal ring on the sphere’s
surface by reducing the search volume. This considerably decreases startup and reacquisition times. (See
Figure 3-2
)
Figure 3-2: Vector G1’s tilt aiding
Gyro Aiding
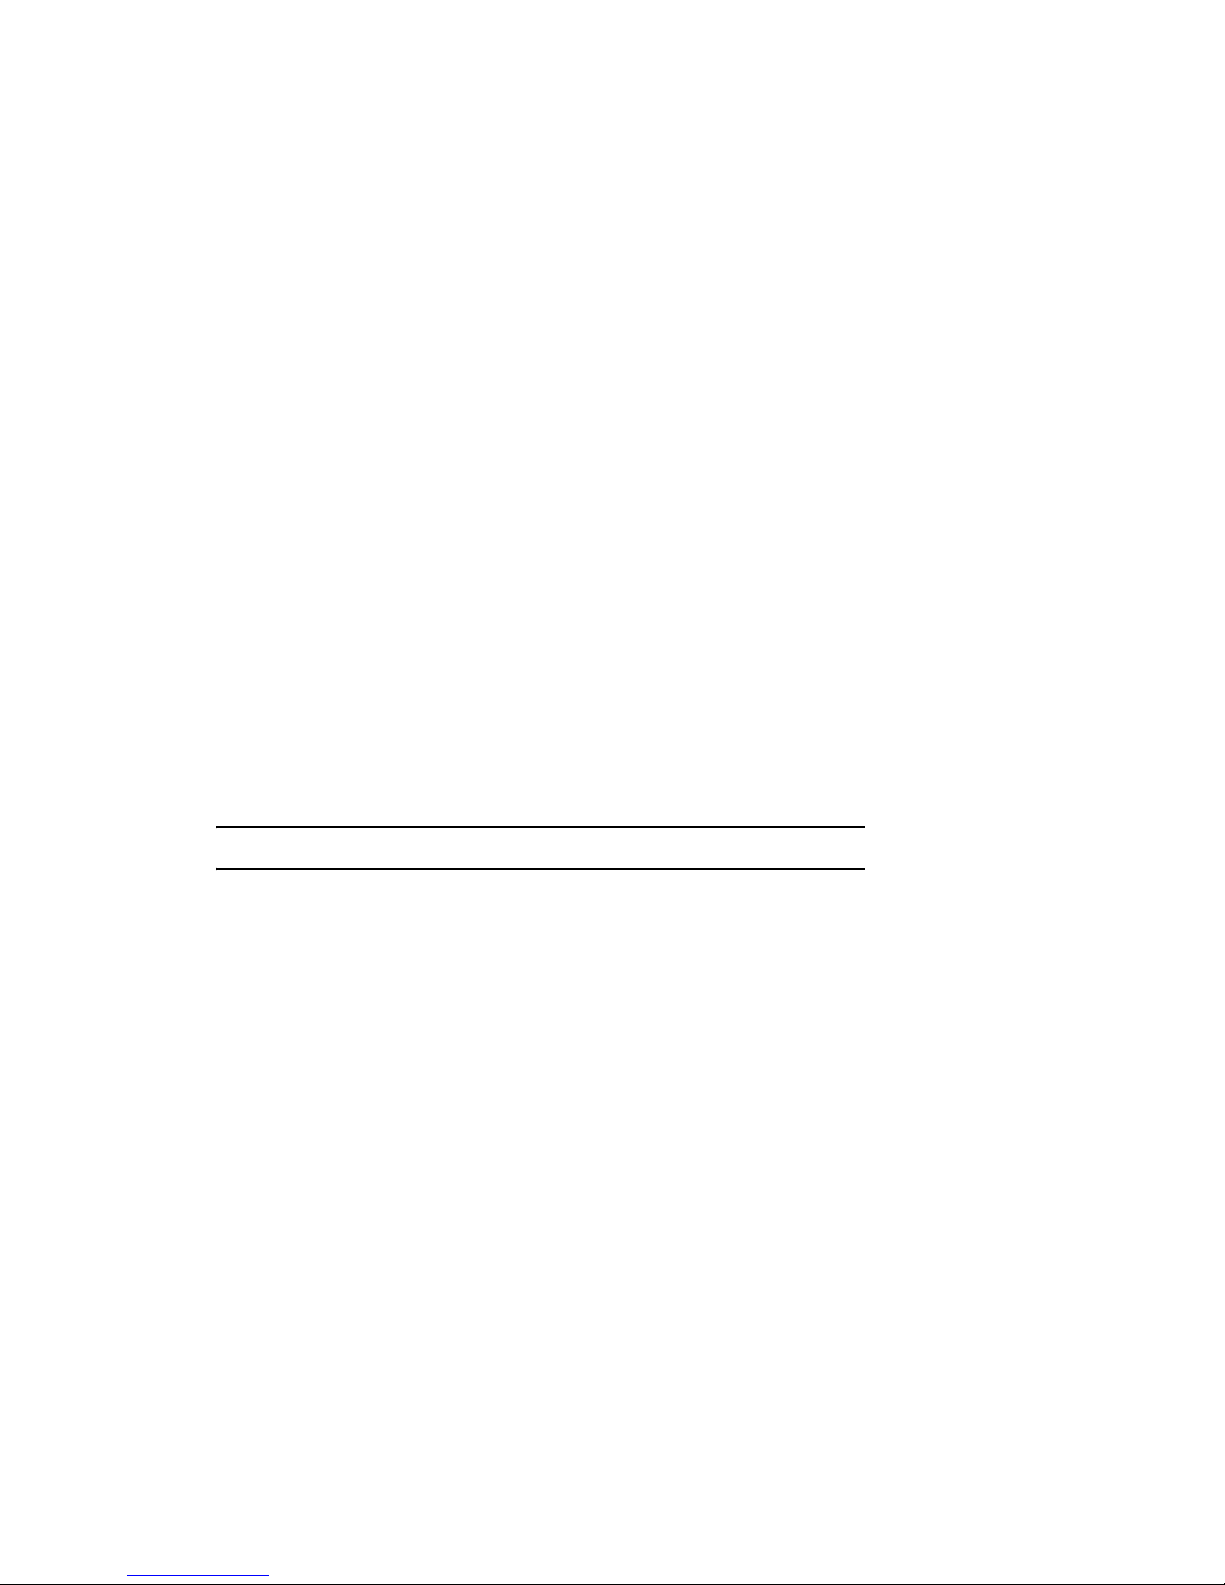
The G1’s internal gyro offers several benefits. It reduces the sensor volume for an RTK solution. This
shortens reacquisition times when a GPS heading is lost because the satellite signals were blocked. The gyro
provides a relative change in angle since the last computed heading, and, when used in conjunction with the
tilt sensor, defines the search space as a wedge-shaped location. (See Figure 3-3
Figure 3-3: Vector G1’s gyro aiding
)
The gyro aiding accurately smoothes the heading output and the rate of turn. It provides an accurate
substitute heading for a short period depending on the roll and pitch of the vessel, ideally seeing the system
through to reacquisition. The gyro provides an alternate source of heading, accurate to within 1º for up to
three minutes, in times of GPS loss for either antenna. If the outage lasts longer than three minutes, the gyro
24
27
Page 30
Chapter 3: Operation
will have drifted too far and the G1 begins outputting null fields in the heading output messages. There is no
user control over the timeout period of the gyro.
Calibration, which is set at the factory, is required for the gyro to remove latency from the heading solution
as well as provide backup heading when GPS is blocked. The receiver will calibrate itself after running for a
while but it may be important to follow the manual calibration instructions if you want to guarantee
performance quickly after powering up the receiver.
The gyro initializes itself at powerup and during initialization, or you can calibrate it using $JATT. When the
gyro is first initializing, it is important that the dynamics that the gyro experiences during this warmup
period are similar to the regular operating dynamics. For example, if you use the G1 on a high speed,
maneuverable craft, it is essential that when gyro aiding in the G1 is first turned on, use it in an environment
that has high dynamics for the first five to ten minutes instead of sitting stationary.
With the gyro enabled, the gyro is also used to update the post HTAU smoothed heading output from the
moving base station RTK GPS heading computation. This means that if the HTAU value is increased while
gyro aiding is enabled, there will be little to no lag in heading output due to vehicle maneuvers. Setting an
appropriate HTAU value for the application is further discussion later.
Time Constants
The G1 incorporates user-configurable time constants that can provide a degree of smoothing to the heading,
course over ground (COG), and speed measurements. You can adjust these parameters depending on the
expected dynamics of the vessel. For example, increasing the time is reasonable if the vessel is very large
and is not able to turn quickly or would not pitch quickly. The resulting values would have reduced “noise,”
resulting in consistent values with time. However, if the vessel is quick and nimble, increasing this value can
create a lag in measurements. If you are unsure on how to set this value, it is best to be conservative and
leave it at the default setting.
Note: There is no lag once the gyro is calibrated and enabled.
Heading time constant: Use the $JATT,HTAU command to adjust the level of responsiveness of the true
heading measurement provided in the $GPHDT message. The default value of this constant is 2.0 seconds of
smoothing when the gyro is enabled. The gyro is enabled by default, but can be turned off. By turning the
gyro off, the equivalent default value of the heading time constant would be 0.5 seconds of smoothing. This
is not automatically done and therefore you must manually enter it. Increasing the time constant increases
the level of heading smoothing and increases lag. You can use the following formula to determine level of
heading smoothing required when the gyro is in use:
htau (in seconds) = 40 / maximum rate of turn (in /sec).
When the gyro is disabled, the formula is: htau (in seconds) = 10 / maximum rate of turn (in /sec)
Pitch time constant: Use the $JATT,PTAU command to adjust the level of responsiveness of the pitch
measurement provided in the $PSAT,HPR message. The default value of this constant is 0.5 seconds of
smoothing. Increasing the time constant increases the level of pitch smoothing and increases lag. you can
use the following formula to determine the level of pitch smoothing required: ptau (in seconds) = 10 /
maximum rate of pitch (in /sec)
Heading Rate time constant: Use the $JATT,HRTAU command to adjust the level of responsiveness of the
rate of heading change measurement provided in the $GPROT message. The default value of this constant is
2.0 seconds of smoothing. Increasing the time constant increases the level of heading smoothing. You can
use the following formula to determine the level of smoothing: hrtau (in seconds) = 10 / maxiumum rate of
the rate of turn (in /sec).
25
28
Page 31
Vector G1 User Guide
Course Over Ground (COG) time constant: Use the $JATT,COGTAU command to adjust the level of
responsiveness of the COG measurement provided in the $GPVTG message. The default value of this
constant is 0.0 seconds of smoothing. Increasing the time constant increases the level of COG smoothing.
COG is computed using only the primary GPS antenna and its accuracy depends upon the speed of the
vessel (noise is proportional to 1/speed). This value is invalid when the vessel is stationary, as tiny
movements due to calculation inaccuracies are not representative of a vessel’s movement. You can use the
following formula to determine COGTAU: cogtau (in seconds) = 10 / maximum rate of change of course (in
degree/sec).
Speed time constant: Use the $JATT,SPDTAU command to adjust the level of responsiveness of the speed
measurement provided in the $GPVTG message. The default value of this constant is 0.0 seconds of
smoothing. Increasing the time constant increases the level of speed measurement smoothing
.
Watchdog
The watchdog is a timer that is controlled by the software that monitors if the heading is lost. The watchdog
software is compliant with IEC 60495.
26
29
Page 32
Chapter 3: Operation
Messages and Configuration Commands
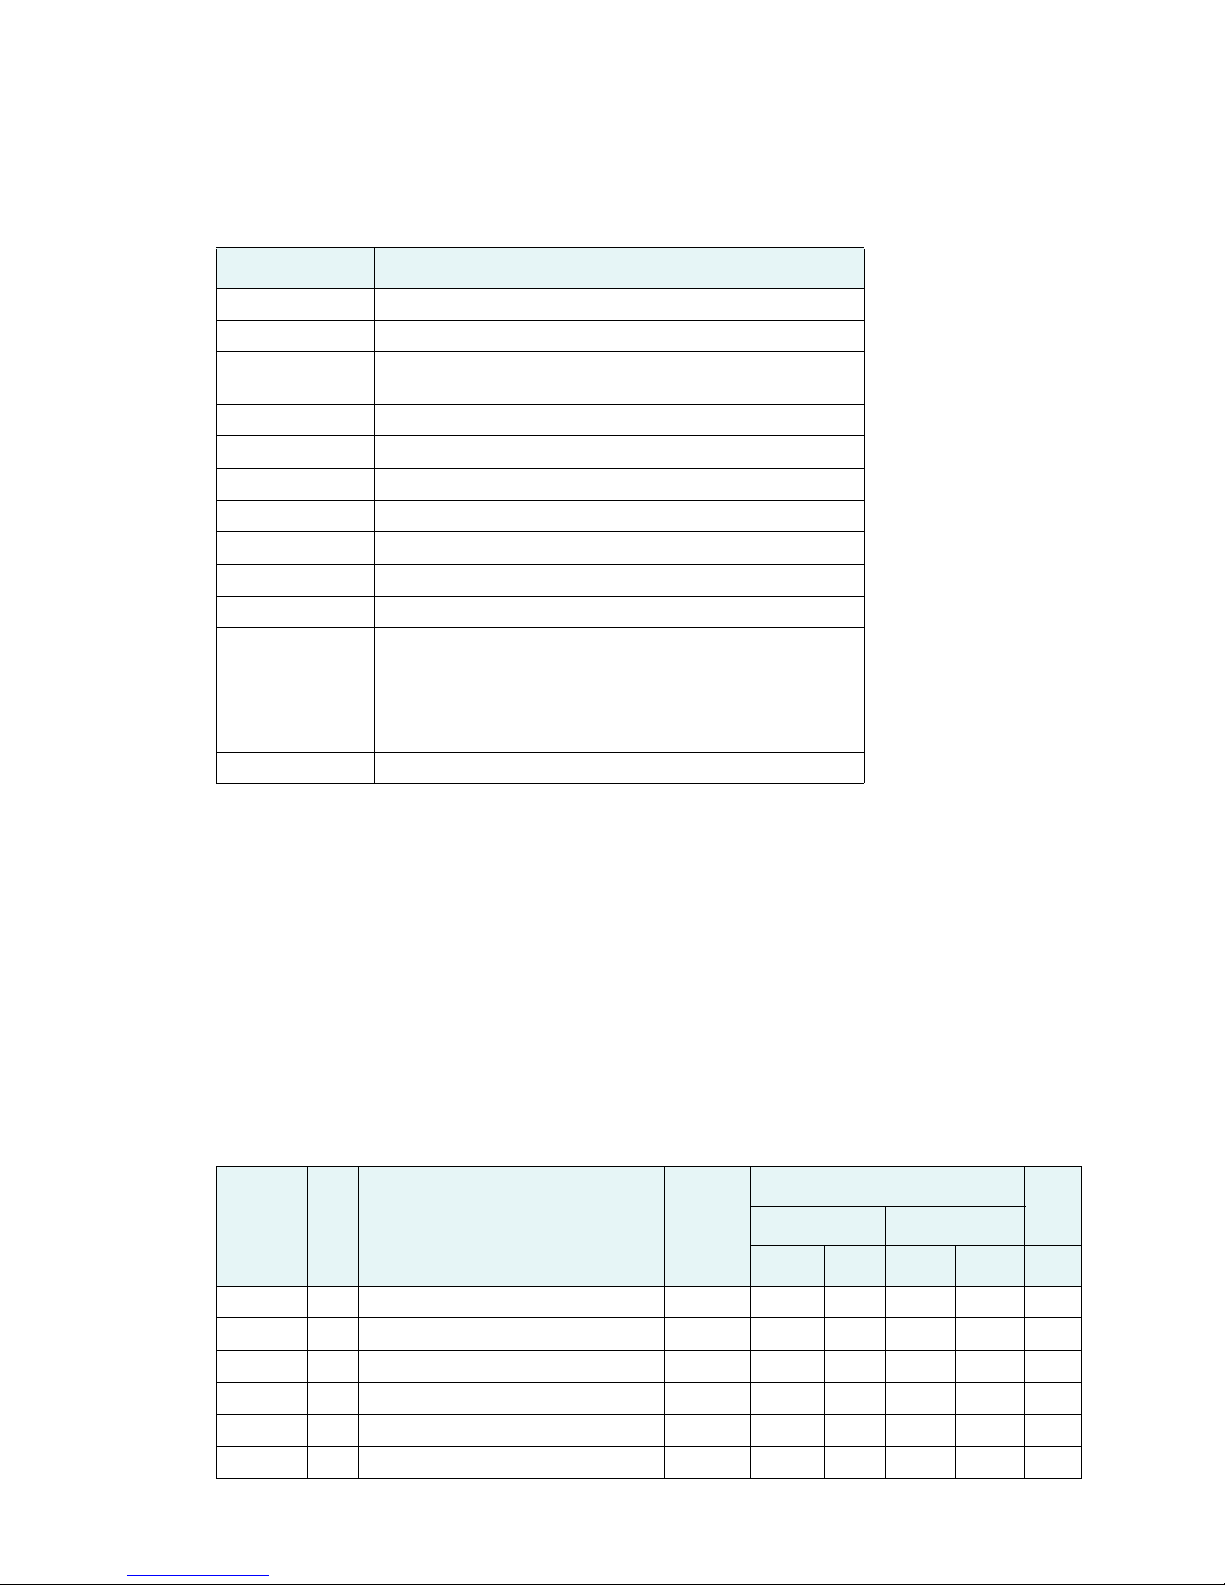
Table 3-2: Commands
Command Description
$JAGE Specify maximum DGPS (COAST) correction age (6 to 8100 seconds)
$JAPP Query or specify receiver application firmware
$JASC Specify ASCII messages to output to specific ports (see ASCII messages
in Table 3-3)
$JBAUD Specify RS-232 (output) communication rate
$JBIN Specify binary messages to output to specific ports (see Table 3-4)
$JDIFF Query or specify differential correction mode
$JGEO Query or specify SBAS for current location and SBAS satellites
$JI Query unit’s serial number and firmware versions
$JOFF Turn off all data messages
$JQUERY,GUIDE Query accuracy suitability for navigation
$JRESET Reset unit’s configuration to firmware defaults
Note: $JRESET clears all parameters. For the
the $JATT, FLIPBRD,YES command to properly redefine the circuitry
orientation inside the product once the receiver has reset. Failure to do so
will cause radical heading behavior.
$JSAVE Save session’s configuration changes
G1 you will have to issue
NMEA Output
The following NMEA 0183 & proprietary data output messages are the ones most commonly used on the Vector G1 (for
others, see the next 3 pages). Factory enabled messages are shown in Grey, and the default repeat rate is shown in the
default column. Factory disabled sentences are shown with an X. Once the Vector G1 is installed and setup correctly,
record in the User column any changes you made for future reference.
In Table 3-3 the Info Type value is one of the following:
• P = Position
• V = Velocity, Time
• H = Heading, Attitude
• S = Sats, Stats, Quality
Table 3-3: NMEA 0183 and other messages
Enabled
Message
$GPDTM P Datum reference Yes X X 1
$GPGGA P GPS position and fix data Yes X X 20
$GPGLL P Geographic position - lat/long Yes 1 X 20
$GPGNS P GNSS position and fix data Yes X X 20
$GPGRS S GNSS range residual (RAIM) Yes X X 20
$GPGSA S GNSS DOP and active satellites Yes X X 1
Info
Typ e
Description
IEC
Approved
Message
Port A Port B
Default User Default User
Max
Rate
27
30
Page 33
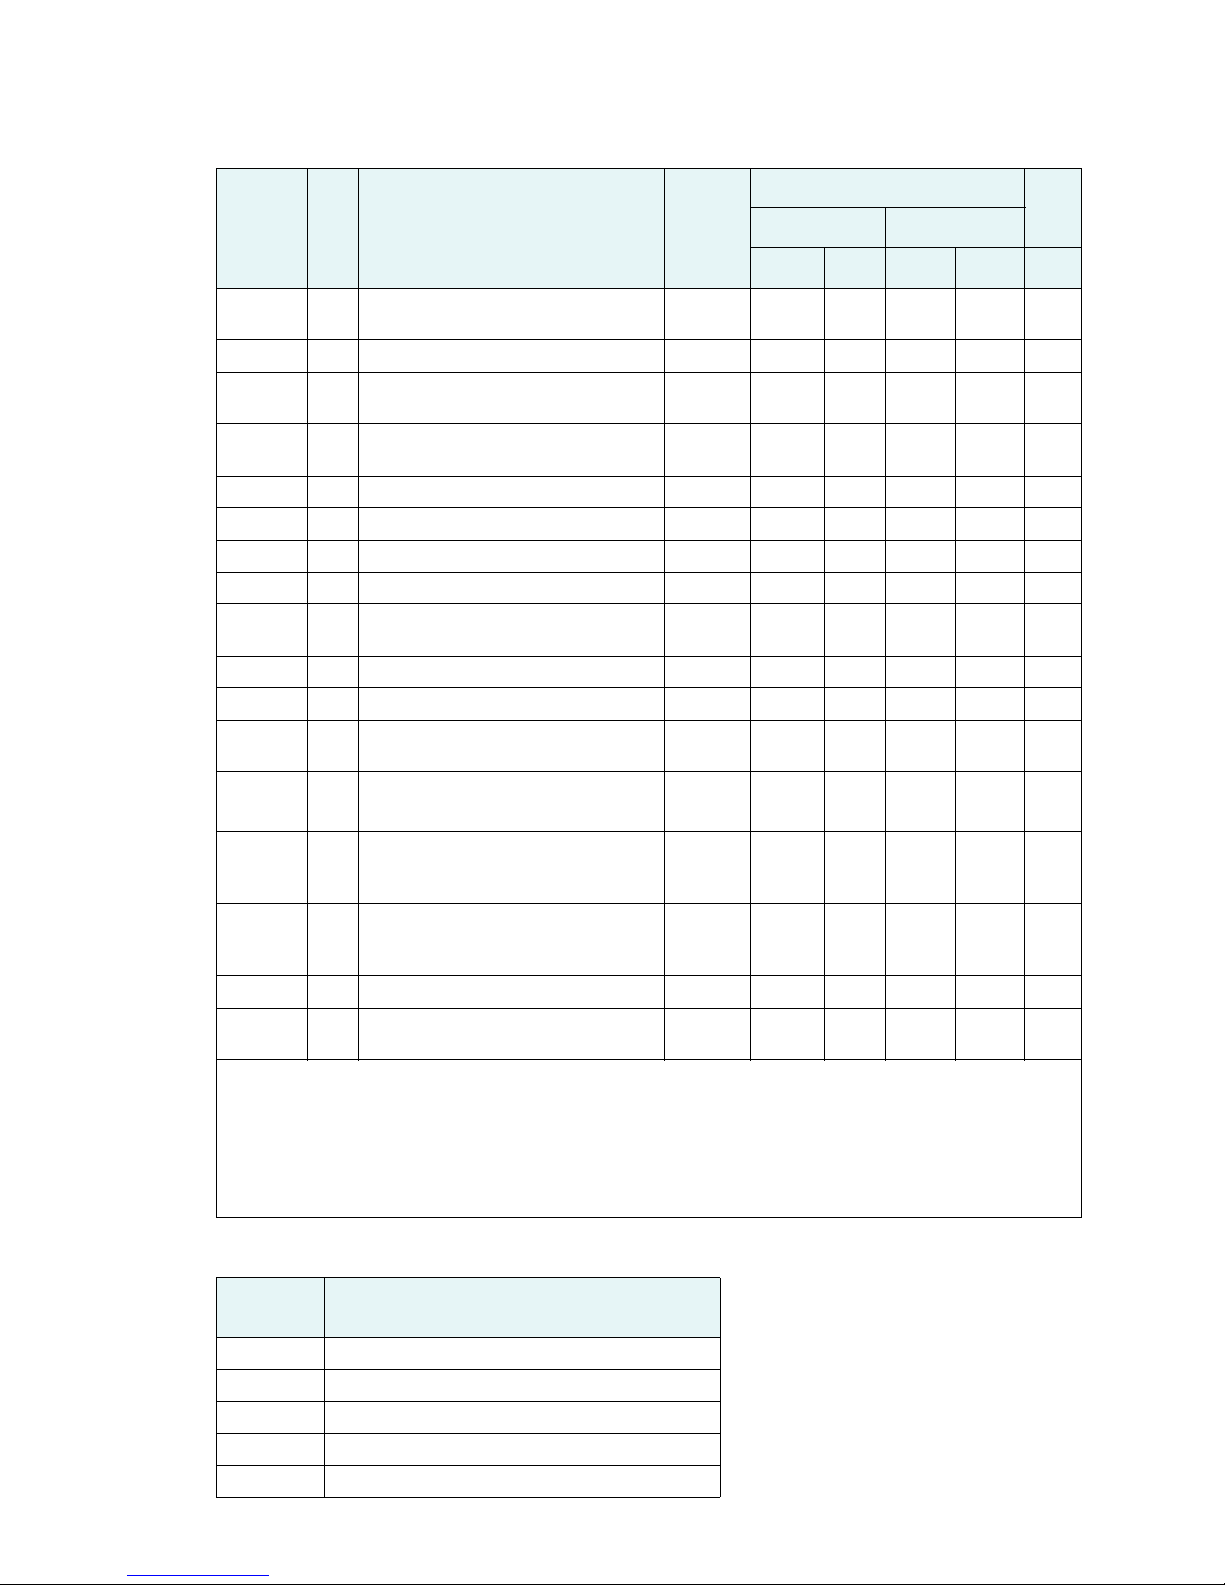
Table 3-3: NMEA 0183 and other messages (continued)
Vector G1 User Guide
Enabled
Message
$GPGST S GNSS pseudo range error statistics and
$GPGSV S GNSS satellites in view Yes X X 1
*$GPHDG H Provides magnetic deviation and variation for
*$GPHDM H Magnetic heading (based on GPS-derived
*$GPHDT H GPS-derived true heading Yes 1 10 20
$GPHEV H Heave value (in meters) Yes X X 20
$GPRMC P Recommended minimum specific GNSS data Yes X X 20
*$GPROT H GPS-derived rate of turn (ROT) Yes 1 X 20
$GPRRE S Range residual and estimated position error
$GPVTG V COG and ground speed Yes 1 1 20
$GPZDA V Time and date Yes 1 X 20
$PASHR H Time, heading, roll, and pitch data in one
$PSAT,
GBS
$PSAT,
HPR
$PSAT,
I NT LT
$RD1 S SBAS diagnostic information Yes X X 1
$TSS1 H Heading, pitch, roll, and heave message in
Notes:
• The GP of the message is the talker ID.
• GPGRS, GPGSA, GPGST, and GPGSV support external integrity checking. They are to be synchronized with
• *You can change the message header for the HDG, HDM, HDT, and ROT messages to either GP or HE using the
Info
Description
Typ e
position accuracy
calculating magnetic or true heading
heading and magnetic declination)
message
message
S Satellite fault detection (RAIM) Yes 1
H Proprietary NMEA message that provides
heading, pitch, roll, and time in single
message
H Proprietary NMEA message that provides the
pitch and roll measurements from the internal
inclinometers (in degrees)
the commonly used TSS1 message format
corresponding fix data (GPGGA or GPGNS).
$JATT,NMEAHE command.
IEC
Approved
Message
Ye s X X 1
Ye s X X 20
No 1 10 20
Ye s X X 1
No 1
No X X 20
Ye s X X 1
No X X 20
Port A Port B
Default User Default User
Max
Rate
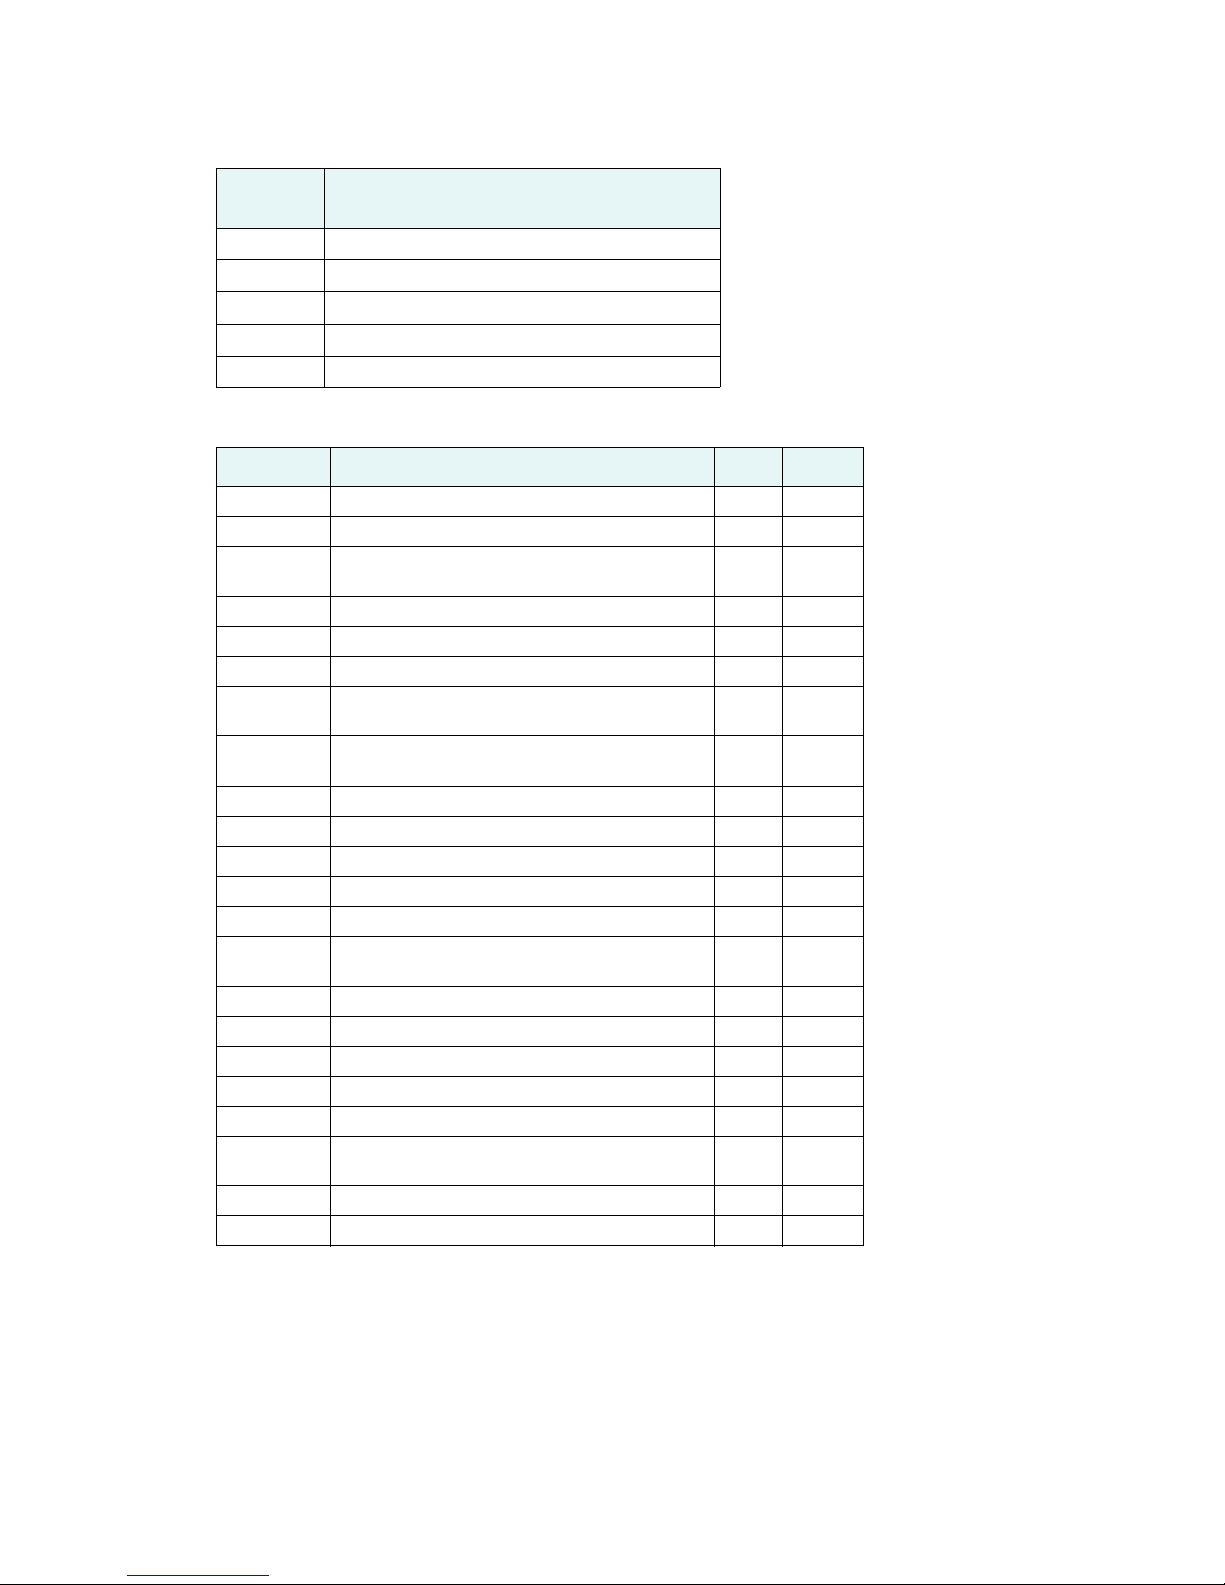
Table 3-4: Binary messages
$JBIN
Message
1 GPS position
2 GPS DOPs
80 SBAS
93 SBAS ephemeris data
94 Ionosphere and UTC conversion parameters
Description
28
31
Page 34
Chapter 3: Operation
Table 3-4: Binary messages (continued)
$JBIN
Message
95 Satellite ephemeris data
96 Code and carrier phase
97 Processor statistics
98 Satellites and almanac
99 GPS diagnostics
Table 3-5: Parameters specific to $JATT command
Parameter Description Query Specify
COGTAU Set/query COG time constant (0.0 to 3600.0 sec) X X
CSEP Query antenna separation X
EXACT Enable/disable internal filter reliance on the entered
FLIPBRD Turn the flip feature on/off X X
GYROAID Enable/disable gyro X X
HBIAS Set/query heading bias (-180.0º to 180.0º) X X
HELP Show the available commands for GPS heading operation
HIGHMP Set/query the high multipath setting for use in poor GPS
HRTAU Set/query time constant (0.0 to 3600.0 sec) X X
HTAU Set/query heading time constant (0.0 to 3600.0 sec) X X
LEVEL Enable/disable level operation X X
MSEP Manually set or query antenna separation X X
NEGTILT Enable/disable negative tilt X X
NMEAHE Change the HDG, HDM, HDT, and ROT message
PBIAS Set/query pitch/roll bias (-15.0º to 15.0º) X X
PTAU Set/query pitch time constant (0.0 to 3600.0 sec) X X
ROLL Configure for roll or pitch GPS orientation X X
SEARCH Force a new GPS heading search X
SPDTAU Set/query speed time constant (0.0 to 3600.0 sec) X X
SUMMARY Display a summary of the current Crescent Vector
TILTAID Enable/disable accelerometer, pre-calibrated X X
TILTCAL Calibrate accelerometers X
Description
XX
antenna separation
X
and status
XX
environments
XX
headers between GP and HE
X
settings
NMEA Configuration commands
The following NMEA-like input sentences can be used to configure the Vector G1.
To query what is the current value of most parameters, leave off the last ",value" portion of the sentence.
For those sentences that enable the output of repeating NMEA data sentences, the range of valid repeat rates is shown in
parentheses; "0" causes the sentence to be disabled. Some sentences may only be disabled or enabled - with a NO or
YES parameter value.
29
32
Page 35
Vector G1 User Guide
The optional parameter PORTX (without the square brackets), where applicable, causes the configuration parameter to
be applied to the other port these sentences are NOT sent from. For example, if you send this command from Port A to
configure Port C, you should add "PORTC" to the command; if you send this command from Port C to configure Port A,
you should add PORTA.
Caution! These commands will affect the
performance of the Vector G1. Improper settings may
result in degradation of system output that can affect
the overall safety of vessels and personnel.
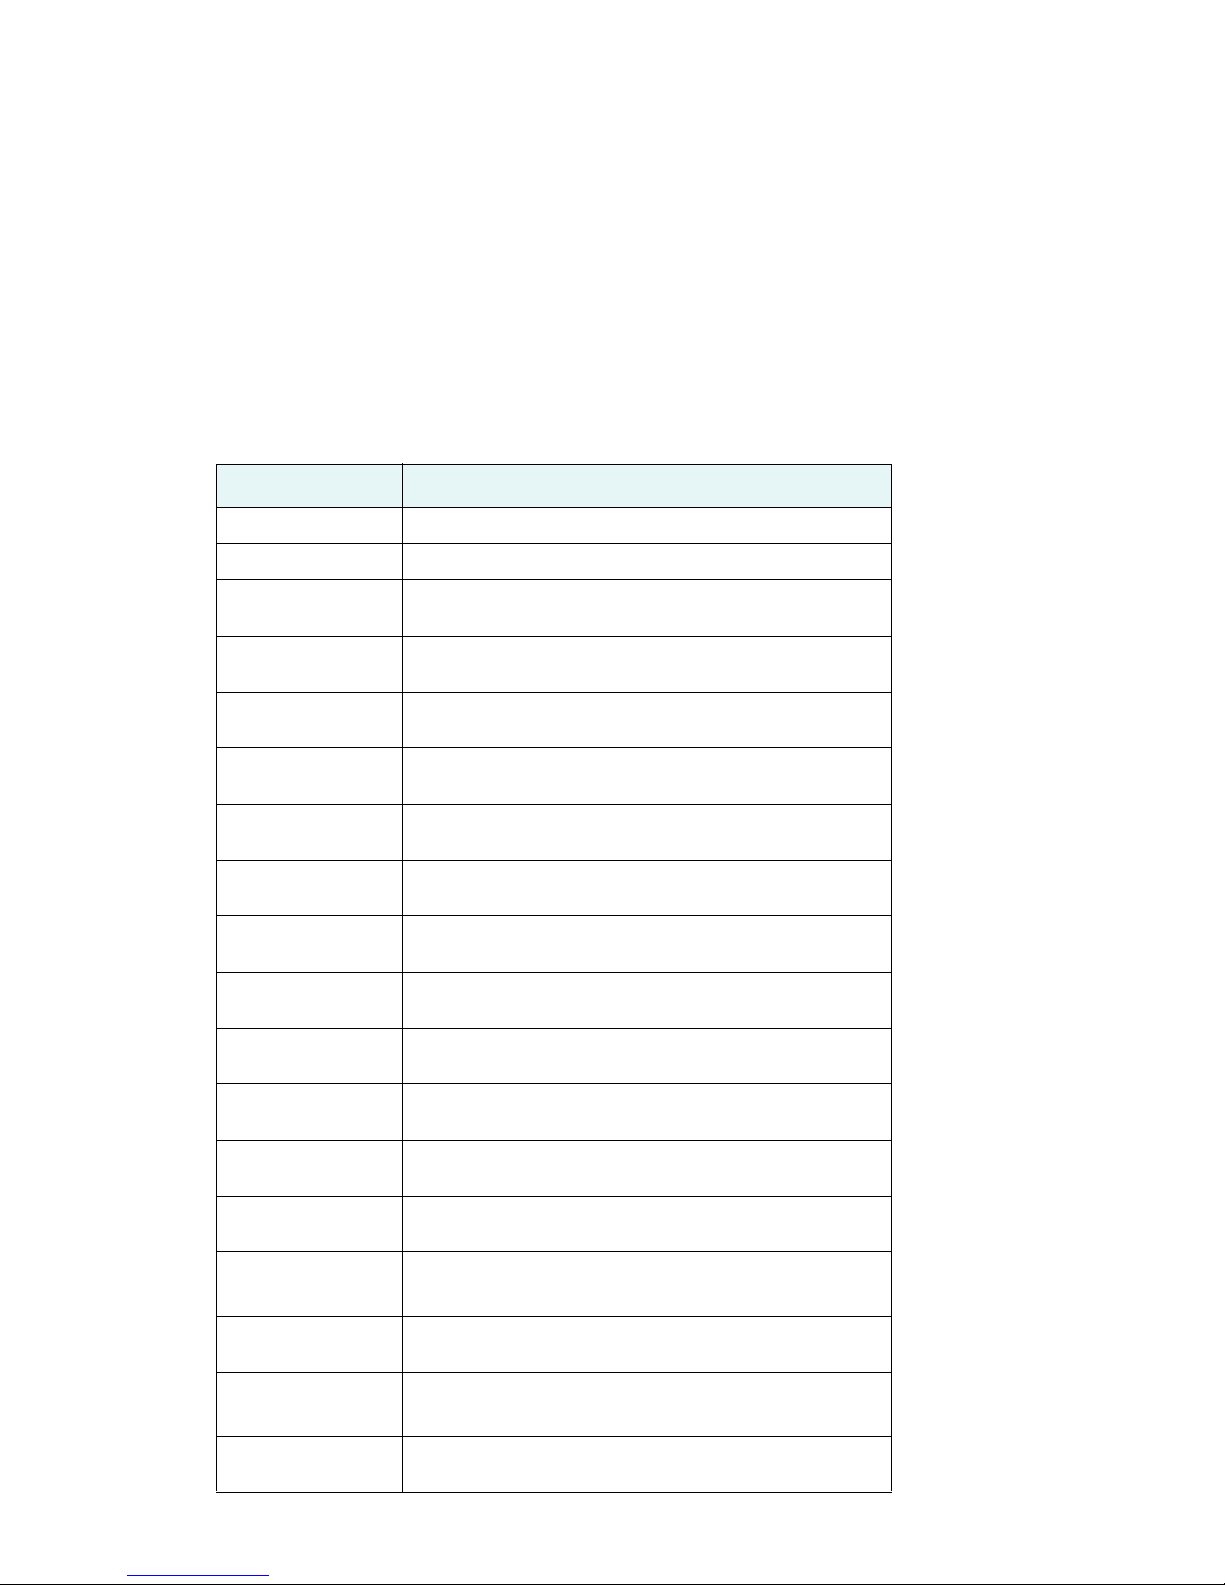
Table 3-6: NMEA Configuration Sentences
Command Description
$JAGE,age[,PORTX] Set Differential Age Timeout (6 to 8100 seconds)
$JASC,D1,rate[,PORTX] Output SBAS diagnostic information (rate = 0 or 1 Hz)
$JASC,GPDTM,rate[,PO
RTX ]
$JASC,GPGGA,rate[,PO
RTX ]
$JASC,GPGLL,rate[,POR
TX]
$JASC,GPGNS,rate[,POR
TX]
$JASC,GPGRS,rate[,POR
TX]
$JASC,GPGSA,rate[,POR
TX]
$JASC,GPGST,rate[,POR
TX]
$JASC,GPGSV,rate[,POR
TX]
$JASC,GPHDG,rate[,PO
RTX ]
$JASC,GPHDM,rate[,PO
RTX ]
$JASC,GPHDT,rate[,POR
TX]
Output Datum Reference information (rate = 0 or 1 Hz)
Output GPS Fix data (rate = 0, 0.2, 1, 5, 10 or 20 Hz)
Output Geographic position (rate = 0, 0.2, 1, 5, 10 or 20 Hz)
Output GNSS Fix data (rate = 0, 0.2, 1, 5, 10 or 20 Hz)
Output GNSS Range Residual data (rate = 0, 0.2, 1, 5, 10 or 20 Hz)
Output GNSS DOP and Active Satellites (rate = 0 or 1 Hz)
Output Pseudorange Error Statistics (rate = 0 or 1 Hz)
Output Satellites in View (rate = 0 or 1 Hz)
Output Generic Heading (rate = 0, 0.2, 1, 5, 10 or 20 Hz)
Output Magnetic Heading (rate = 0, 0.2, 1, 5, 10 or 20 Hz)
Output True Heading (rate = 0, 0.2, 1, 5, 10 or 20 Hz)
$JASC,GPROT,rate[,POR
TX]
$JASC,GPRMC,rate[,PO
RTX ]
$JASC,GPRRE,rate[,POR
TX]
$JASC,GPVTG,rate[,POR
TX]
$JASC,GPZDA,rate[,PO
RTX ]
Output Rate Of Turn (rate = 0, 0.2, 1, 5, 10 or 20 Hz)
Output Recommended Minimum Specific GNSS data
(rate = 0, 0.2, 1, 5, 10 or 20 Hz)
Output Range Residual Error data (rate = 0 or 1 Hz)
Output Course Over Ground and Speed Over Ground data
(rate = 0, 0.2, 1, 5, 10 or 20 Hz)
Output Time and Date (rate = 0, 0.2, 1, 5, 10 or 20 Hz)
33
30
Page 36
Chapter 3: Operation
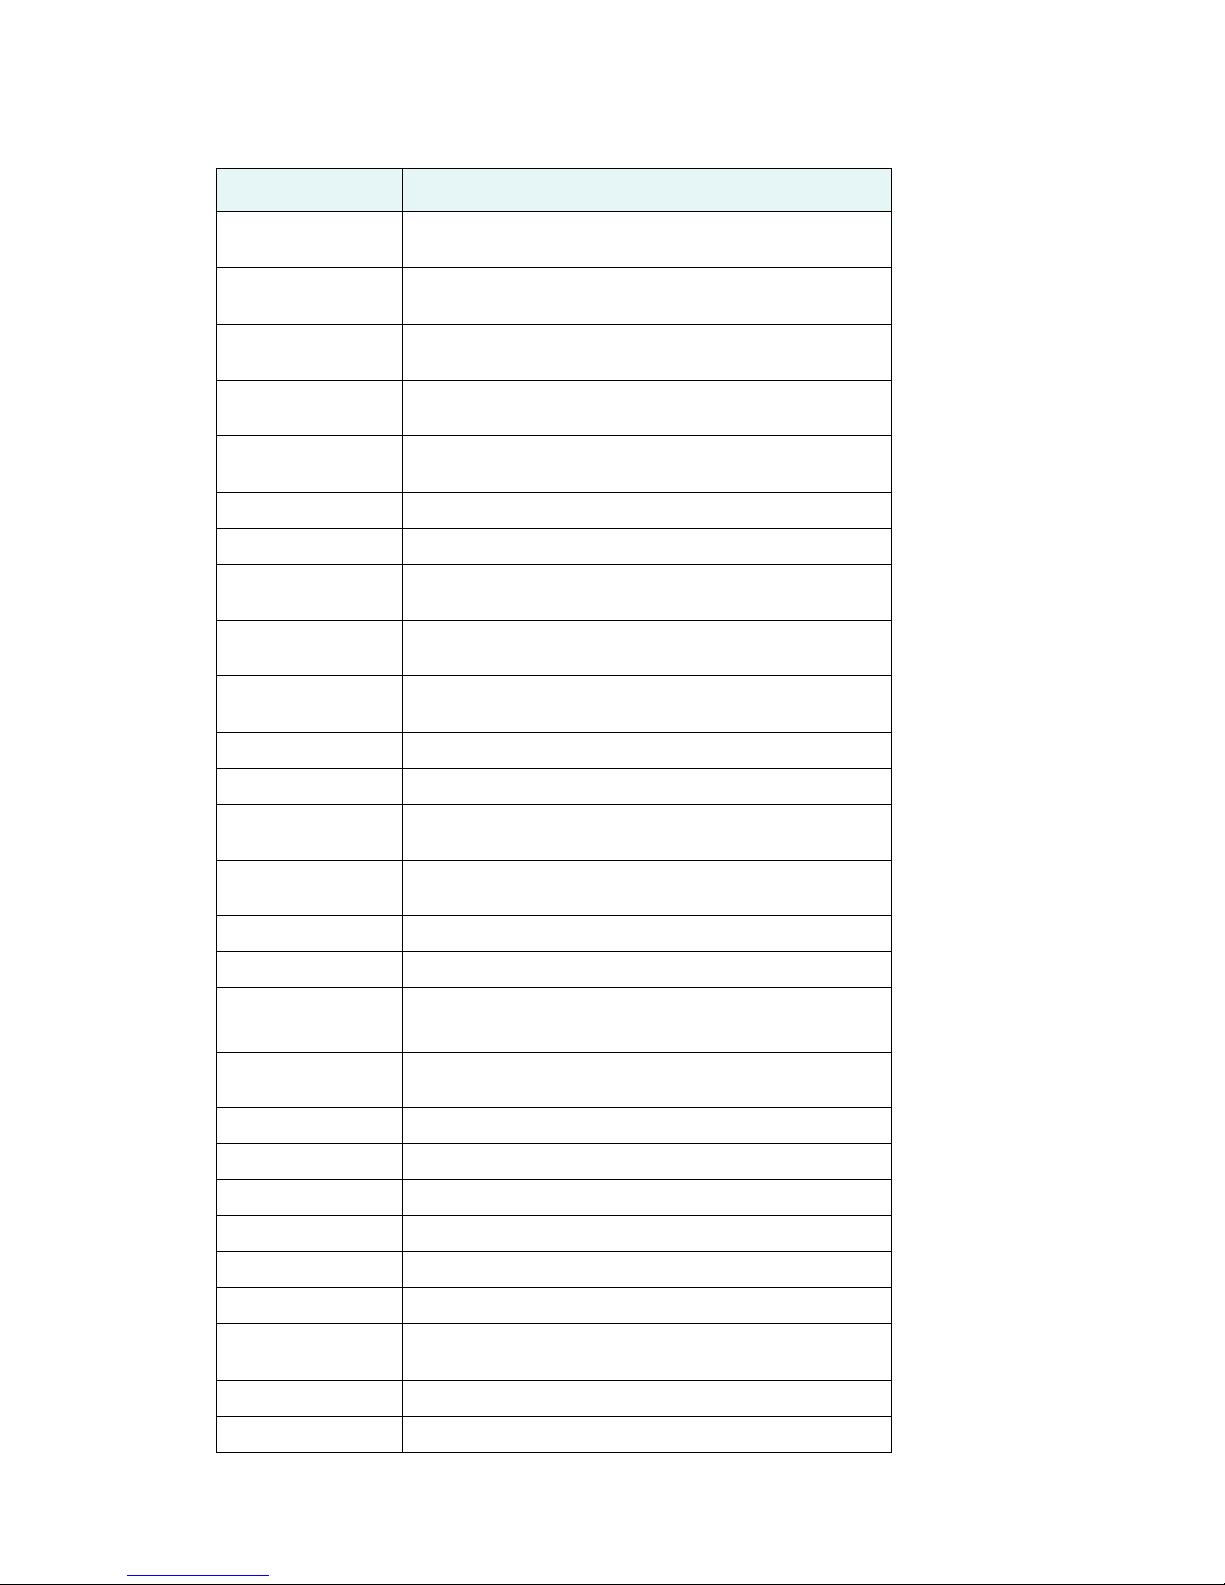
Table 3-6: NMEA Configuration Sentences
Command Description
$JASC,PASHR,rate[,POR
TX]
$JASC,GPHPR,rate[,POR
TX]
$JASC,INTLT,rate[,PORTX]Output Internal Tilt sensor measurement (rate = 0 or 1 Hz)
$JASC,GPGBS,rate[,POR
TX]
$JASC,PTSS1,rate[,POR
TX]
$JATT,COGTAU,cogtau Query or Set Course Smoothing Time (cogtau = 0.0 to 3600.0 seconds)
$JATT,CSEP Query Current Antenna Separation
$JATT,EXACT,NO/YES Query or Disable/enable the internal filter reliance on the entered antenna
$JATT,FLIPBRD,NO/
YES
$JATT,GYROAID,NO/
YES
$JATT,HBIAS,hbias Query or Set Heading Output Offset (range is -180° to +180°) *
$JATT,HELP Provide a short list of commands available
Output time, heading, roll, and pitch data in one message (rate = 0 or 1
Hz)
Output heading and pitch (or roll) data (rate = 0, 0.2, 1, 5, 10 or 20 Hz)
Output Receiver Autonomous Integrity Monitoring (RAIM) (rate = 0 or 1
Hz)
Output Heading, pitch, roll, and heave in TSS1 message format (rate = 0,
0.2, 1, 5, 10 or 20 Hz)
separation
Query the current flip feature status or turn off/on it. When the flip feature
is turned off, the board is installed right side up (default mode).
Query or Disable/Enable the Gyro-Aid function
$JATT,HIGHMP,NO/YES Query or Disable/enable the high multipath setting for use in poor GPS
environment
$JATT,HRTAU,hrtau Query or Set Rate of Turn Smoothing Time (hrtau = 0.0 to 3600.0
$JATT,HTAU,htau Query or Set Heading Smoothing Time (htau = 0.0 to 3600.0 seconds)
$JATT,LEVEL,NO/YES Query or Disable/Enable Level Mode Operation
$JATT,MSEP,sep Manually set antenna separation
$JATT,NEGTILT,NO/
YES
$JATT,NMEAHE,0 Set Talker ID for HDG, HDM & HDT sentences to GP
$JATT,NMEAHE,1 Set Talker ID for HDG & HDT sentences to HE, and HDM to HC
$JATT,PBIAS,pbias Query or Set Pitch/Roll Bias (range is -15° to +15°)
$JATT,PTAU,ptau Query or Set Pitch Smoothing Time (ptau = 0.0 to 3600.0 seconds)
$JATT,ROLL,NO/YES Query or Set Pitch/Roll function to measure Pitch or Roll *
$JATT,SEARCH Force a new RTK Search
$JATT,SPDTAU,spdtau Query or Set Speed Smoothing Time Constant (spdtau = 0.0 to 200.0
$JATT,SUMMARY Query Current Settings
seconds)
(this cannot be changed on the Vector G1)
Query or Set Normal/Reverse Pitch/Roll sign convention
seconds)
$JATT,TILTAID,NO/YES Query or Disable/Enable the Tilt-Aid function
31
34
Page 37
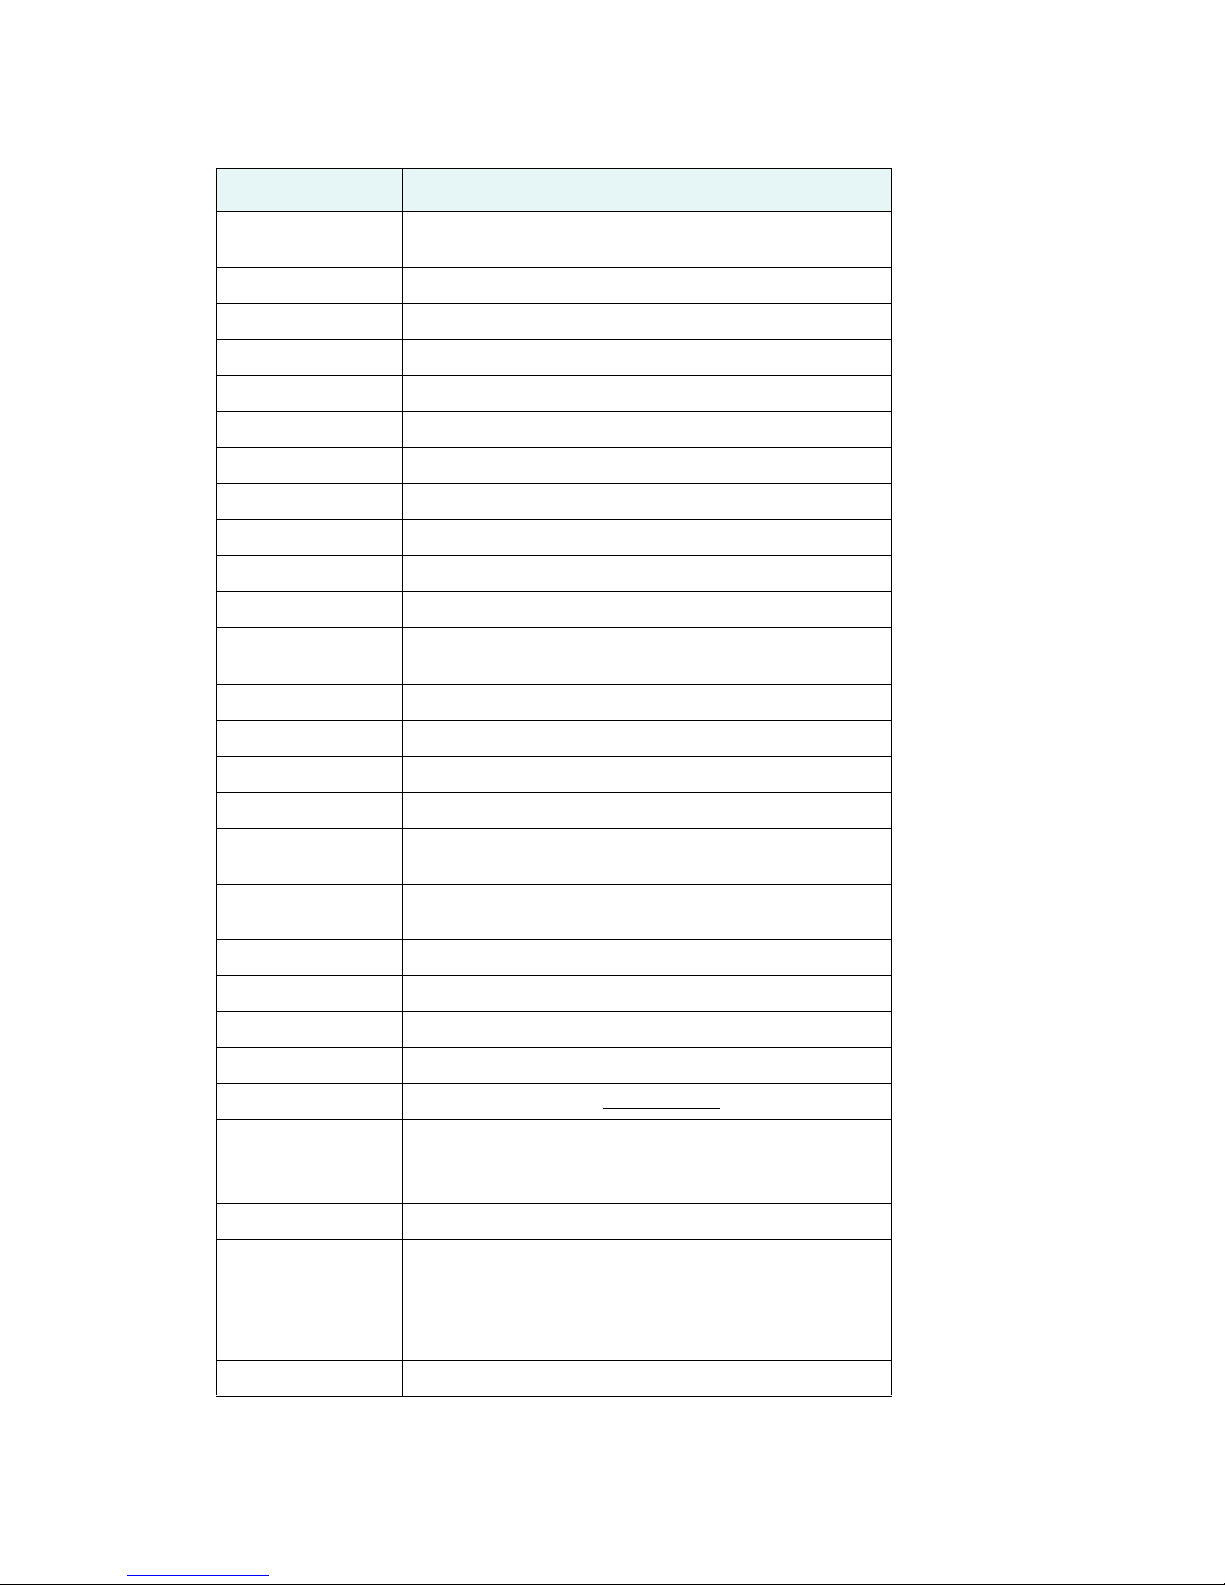
Table 3-6: NMEA Configuration Sentences
Command Description
$JATT,TILTCAL Calibrate the Tilt-Aid sensor (the Vector G2 must be level, and all satellite
signals be blocked, when this command is issued)
$JBAUD,4800[,PORTX] Set Baud rate to 4800
$JBAUD,9600[,PORTX] Set Baud rate to 9600
$JBAUD,19200[,PORTX] Set Baud rate to 19200
$JBAUD,38400[,PORTX] Set Baud rate to 38400
$JBIN,1,rate Output Binary GPS Position (rate = 0, 0.2, 1, 5, 10 or 20 Hz)
$JBIN,2,rate Output Binary GPS DOPs (rate = 0 or 1 Hz)
$JBIN,80,rate Output Binary GPS SBAS information (rate = 0 or 1 Hz)
$JBIN,93,rate Output Binary SBA ephemeris data (rate = 0 or 1 Hz)
$JBIN,94,rate Output Ionosphere & UTC conversion parameters (rate = 0 or 1 Hz)
$JBIN,95,rate Output Binary GPS ephemeris information (rate = 0 or 1 Hz)
$JBIN,96,rate Output Binary code & carrier phase information (rate = 0, 0.2, 1, 5, 10 or
20 Hz)
Vector G1 User Guide
$JBIN,97,rate Output Binary process statistics (rate = 0, 0.2, 1, 5, 10 or 20 Hz)
$JBIN,98,rate Output Binary GPS Satellite & Almanac information (rate = 0 or 1 Hz)
$JBIN,99,rate Output Binary GPS diagnostic information (rate = 0 or 1 Hz)
$JDIFF,NONE Operate in autonomous mode
$JDIFF,PORTX[,SAVE] Use corrections input through PORT C or PORT A. Save the
configuration if 'SAVE' is appended to the command
$JDIFF,WAAS[,SAVE] Use SBAS corrections; save the configuration if 'SAVE' is appended to the
$JGEO Queries frequency and location of SBAS satellites
$JI Query the G2's serial number & firmware revisions
$JOFF Turn off all data output
$JQUERY,GUIDE Query whether the Vector G2 is providing suitable performance or not
$JRESET Reset to default settings** DO NOT USE!!
$JSAVE Save current Configuration
$JSHOW Show current Configuration
$JSMOOTH,time Query or Set Carrier Smoothing Time
command
wait until the Vector replies with "$> Save Complete" before
powering it down!
time = SHORT ==> 300 seconds
time = LONG ==> 900 seconds
time = 15 to 6000 seconds
$JWAASPRN Query PRNs of SBAS satellites currently being used
32
35
Page 38
Chapter 3: Operation
* Use the $JATT,HBIAS & $JATT,ROLL commands if the Vector is installed athwartships:
$J ATT,RO LL,YES
and then (if you have mounted the Vector pointing to Port)
$J ATT,HBIAS,90.0
or (if you have mounted the Vector pointing to Starboard)
$J ATT,HBIAS,-90.0
** This command does not set the configuration parameters to the ComNav factory
default values, but to another OEM set – and so should never be used. If you do
happen to send it by mistake, please call your ComNav Dealer or the ComNav
Service Department for help in restoring the factory defaults.
33
36
Page 39
Appendix A: Troubleshooting
34
37
Page 40
38
Page 41
Appendix A: Troubleshooting
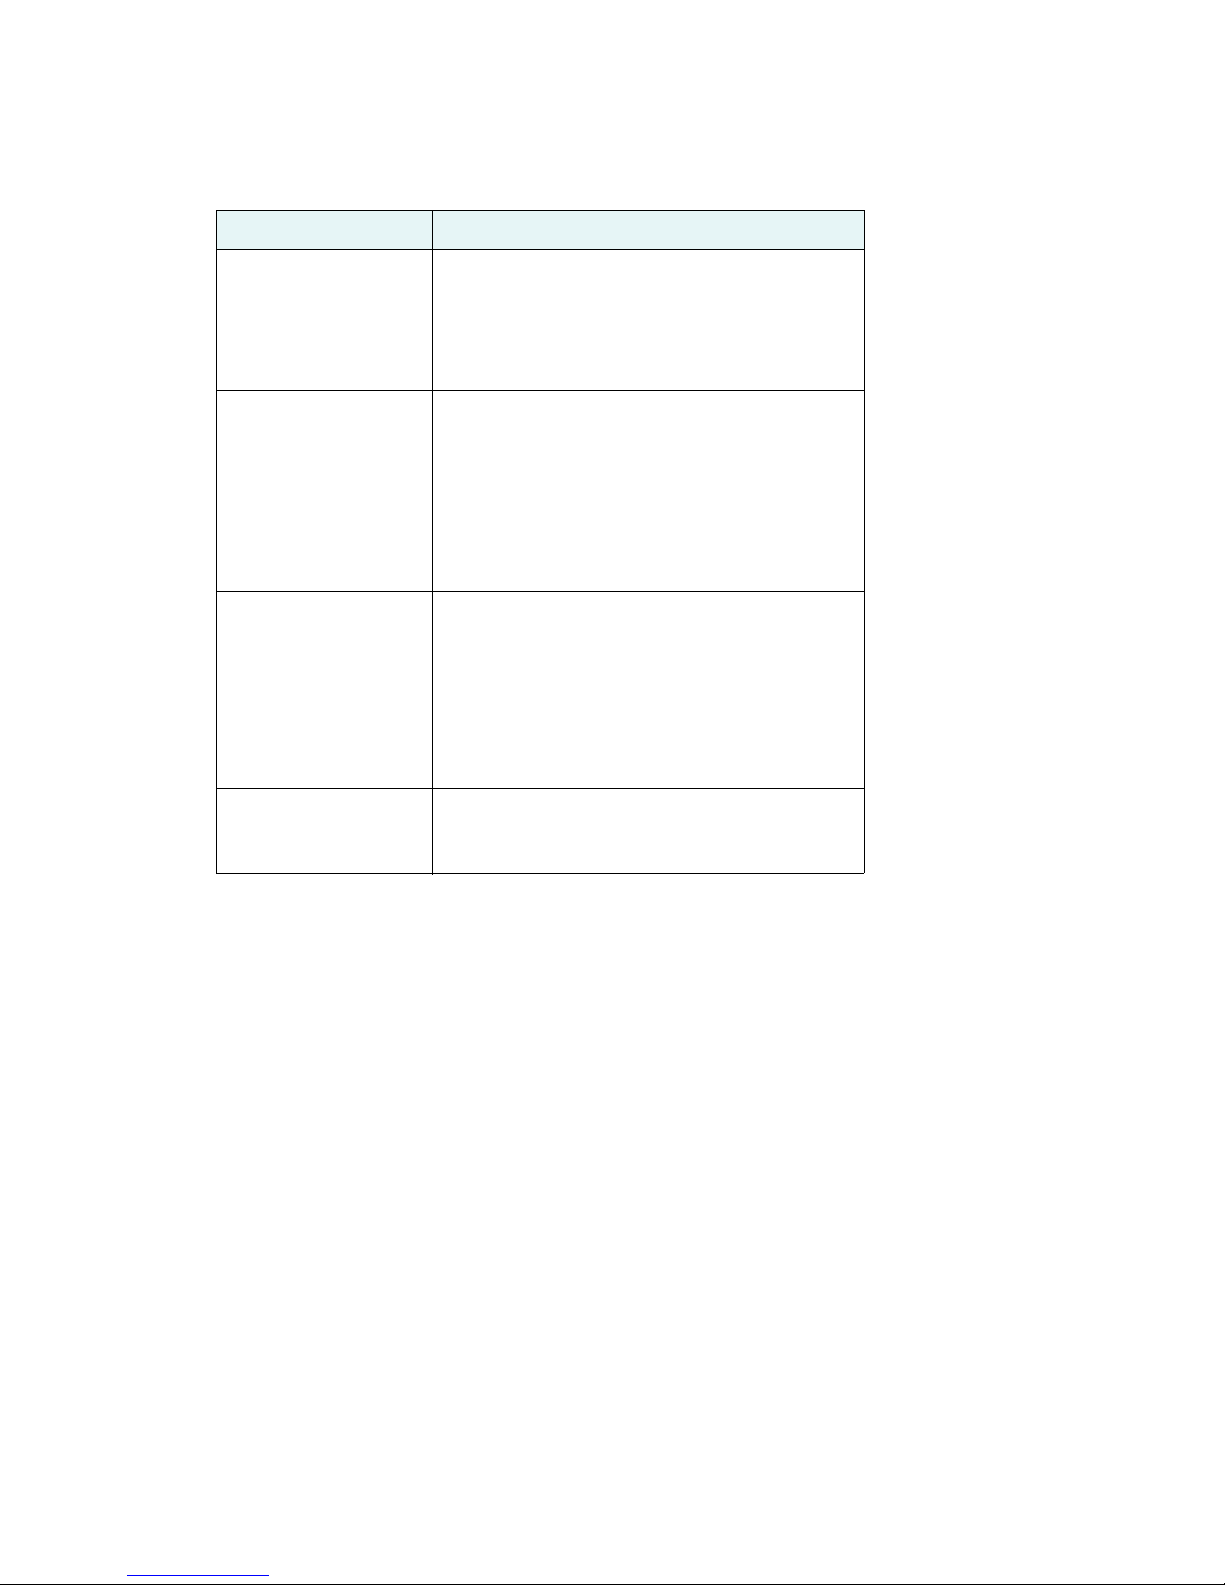
Table A-1 provides troubleshooting for common problems.
Table A-1: Troubleshooting
Symptom Possible Solution
Receiver fails to power • Verify polarity of power leads
• Check integrity of power cable connectors
• Check power input voltage (6 to 36 VDC)
• Check current restrictions imposed by power source
(minimum available should be > 1.0 A)
No data from
Random data from
G1
G1
No GPS lock
• Check receiver power status to ensure the receiver is
powered (an ammeter can be used for this)
• Verify desired messages are activated (using PocketMax or
$JSHOW in any terminal program)
• Ensure the baud rate of the
device
• Check integrity and connectivity of power and data cable
connections
• Verify the RTCM or binary messages are not being output
accidentally (send a $JSHOW command)
• Ensure the baud rate of the
device
• Potentially, the volume of data requested to be output by the
G1 matches that of the receiving
G1 matches that of the remote
G1 could be higher than the current baud rate supports (try
using 19200 as the baud rate for all devices or reduce the
amount of data being output)
• Verify the
• Verify the lock status of GPS satellites (this can be done with
PocketMax)
G1 has a clear view of the sky
35
39
Page 42
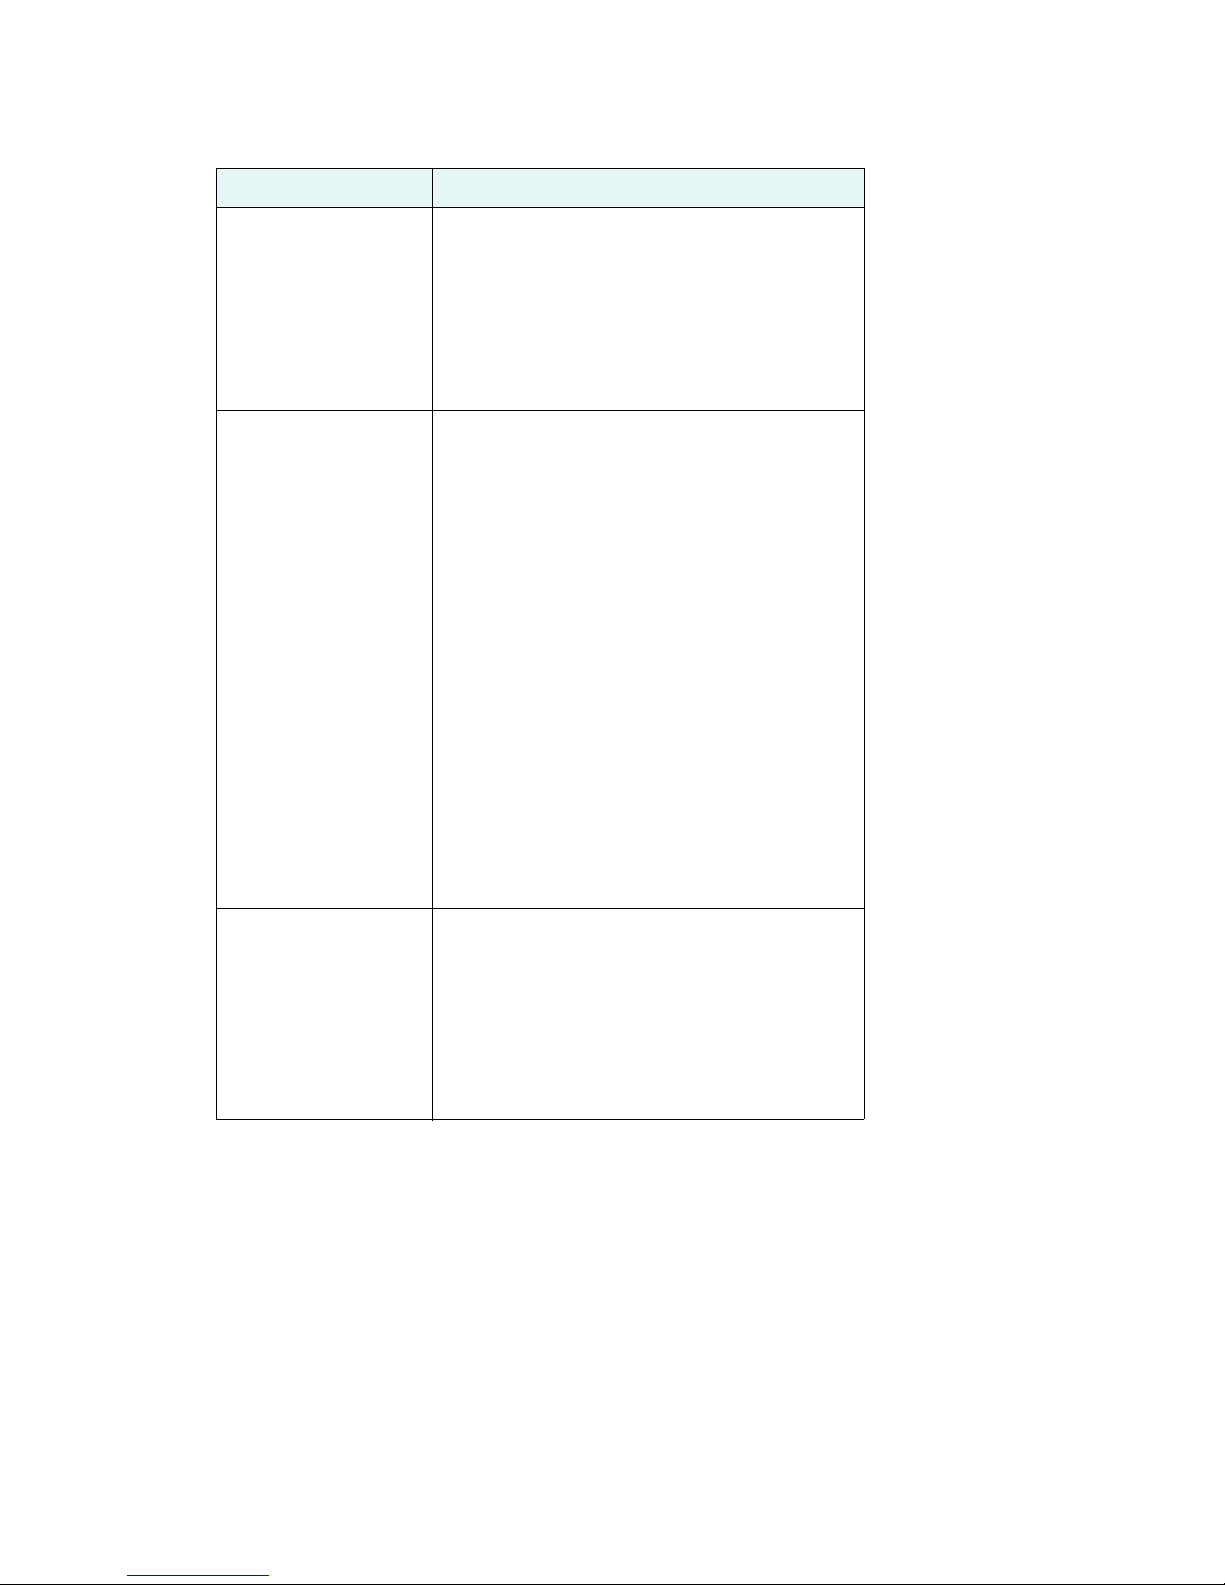
Table A-1: Troubleshooting (continued)
Symptom Possible Solution
Vector G1 User Guide
No SBAS lock
No heading or incorrect
heading value
• Verify the
• Verify the lock status of SBAS satellites (this can be done
with PocketMax - monitor BER value)
• SBAS lock can only get if you are in an appropriate SBAS
region (currently, there is limited SBAS availability in the
southern hemisphere)
• Set SBAS mode to automatic with the $JWAASPRN,AUTO
command
• Check CSEP value is fairly constant without varying more
than 1 cm (0.39 in)—larger variations may indicate a high
multipath environment and require moving the receiver
location
• Recalibrate the tilt sensor with $JATT,TILTCAL command
if heading is calculated then lost at consistent time intervals
• Heading is from primary GPS antenna to secondary GPS
antenna, so the arrow on the underside of the
directed to the bow side
• $JATT,SEARCH command forces the
heading solution (unless gyro is enabled)
• Enable GYROAID to provide heading for up to three
minutes during GPS signal loss
• Enable TILTAID to reduce heading search times
• Monitor the number of satellites and SNR values for both
antennas within PocketMax3—at least four satellites should
have strong SNR values
• Potentially, the volume of data requested to be output by the
G1 has a clear view of the sky
G1 should be
G1 to acquire a new
G1 could be higher than the current baud rate supports (try
using 19200 as the baud rate for all devices or reduce the
amount of data being output)
No DGPS position in external
RTCM mode
• Verify the baud rate of the RTCM input port matches the
baud rate of the external source
• Verify the pinout between the RTCM source and the RTCM
input port (transmit from the source must go to receive of the
RTCM input port and grounds must be connected)
• Ensure corrections are being transmitted to the correct
port—using the $JDIFF,PORTC command on Port A will
cause the receiver to expect the corrections to be input
through Port C
36
40
Page 43
Appendix B: Specifications
38
41
Page 44
42
Page 45
Appendix B: Specifications
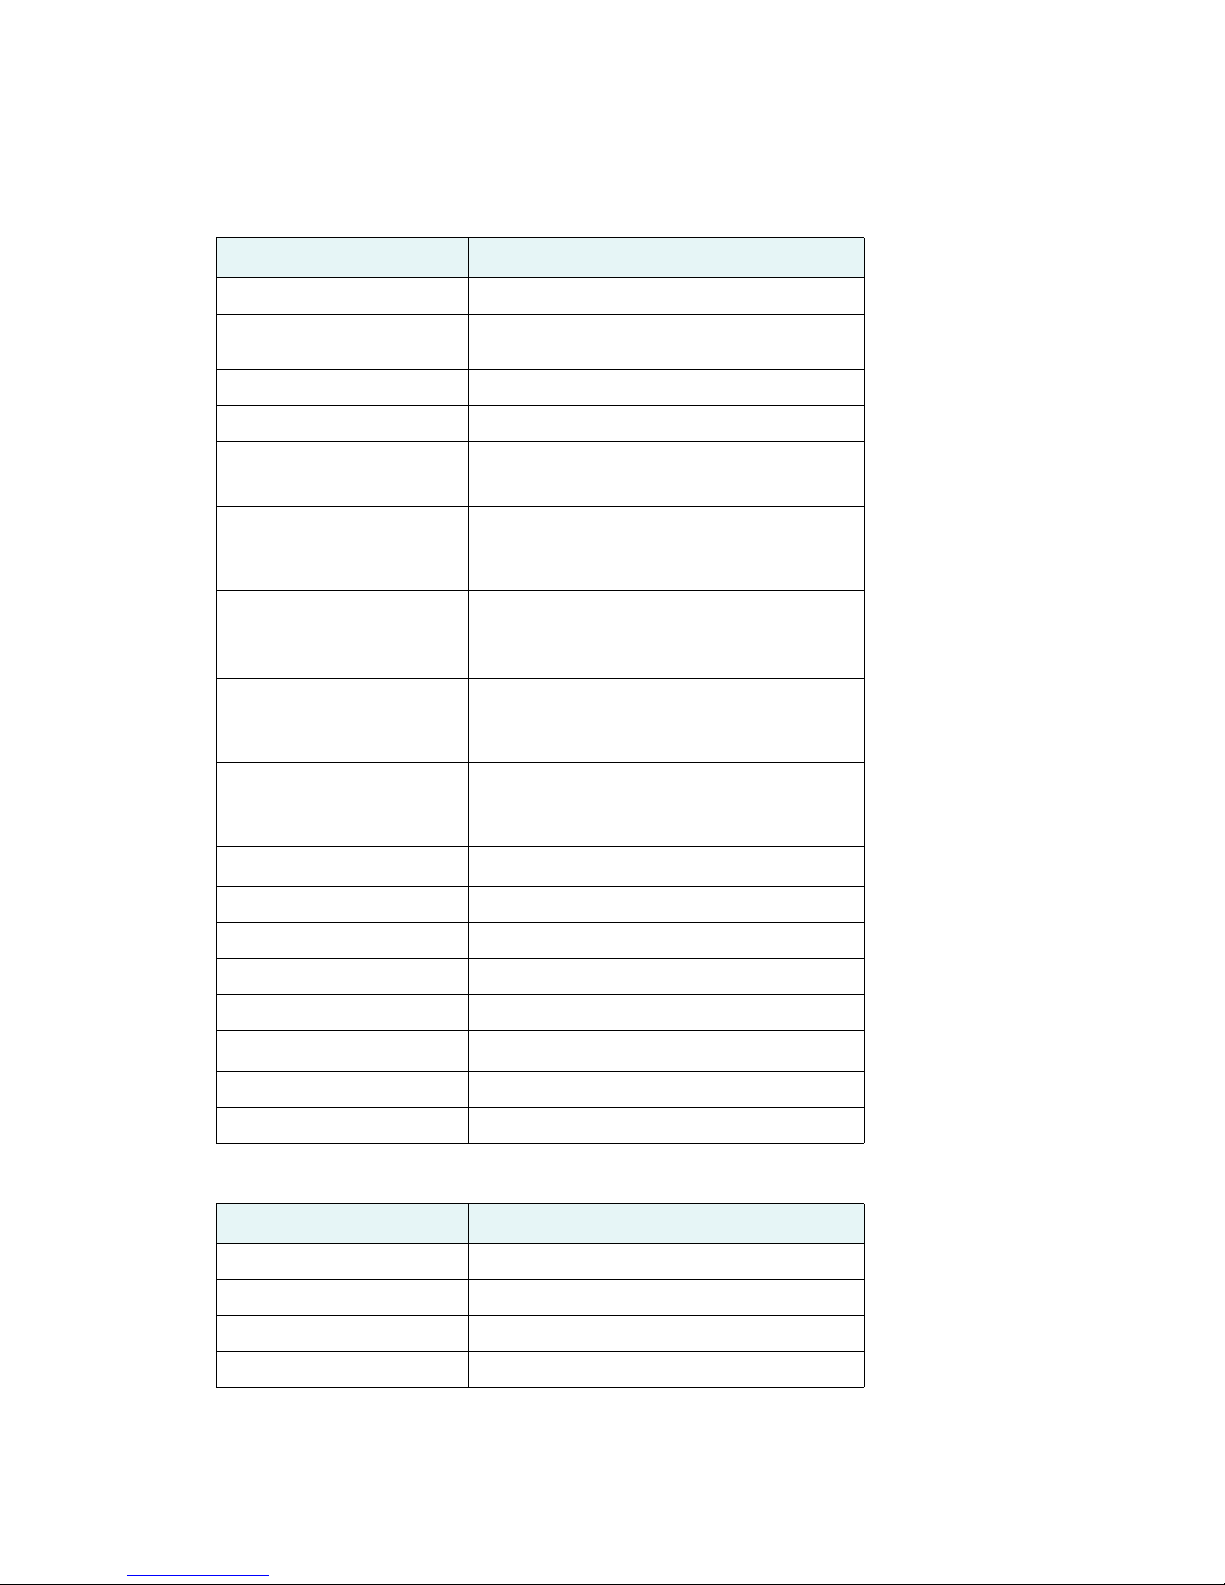
Table B-1 through Table B-5 provide the G1’s GPS sensor, communication, power, mechanical, and
environmental specifications
Table B-1: GPS sensor specifications
Item Specification
Receiver type L1, C/A code with carrier phase smoothing
Channels Two 12-channel, parallel tracking
SBAS tracking 2-channel, parallel tracking
Update rate Standard 10 Hz, optional 20 Hz (position and heading)
Horizontal accuracy
Heading accuracy < 0.60° rms
Heave accuracy
.
(Two 10-channel when tracking SBAS)
< 1.0 m 95% confidence (DGPS
< 4.0 m 95% confidence (autonomous, no SA
Normal operation: GPS
Coasting (no GPS): Gyro
< 30 cm rms
Normal operation: GPS
Coasting (no GPS): None
5
1
)
2
)
Pitch accuracy < 1.5° rms
Normal operation: GPS
Coasting (no GPS): Inertial sensor
Roll accuracy < 1.5° rms using accelerometer
Normal operation: Inertial sensor
Coasting (no GPS): Inertial sensor
Rate of turn
Cold start < 60 s typical (no almanac or RTC)
Warm start < 20 s typical (almanac and RTC)
Hot start < 1 s typical (almanac, RTC, and position)
Heading fix < 10 s typical (valid position)
Compass safe distance
Maximum speed 1,850 kph (999 kts)
Maximum altitude 18,288 m (60,000 ft)
Table B-2: Communication specifications
Item Specification
Serial ports 2 full-duplex RS-232
°/s maximum
90
30 cm (11.8 in)
4
Baud rates 4800, 9600, 19200, 38400, 57600, 115200
Correction I/O protocol RTCM SC-104
Data I/O protocol NMEA 0183, NMEA 2000
39
43
Page 46
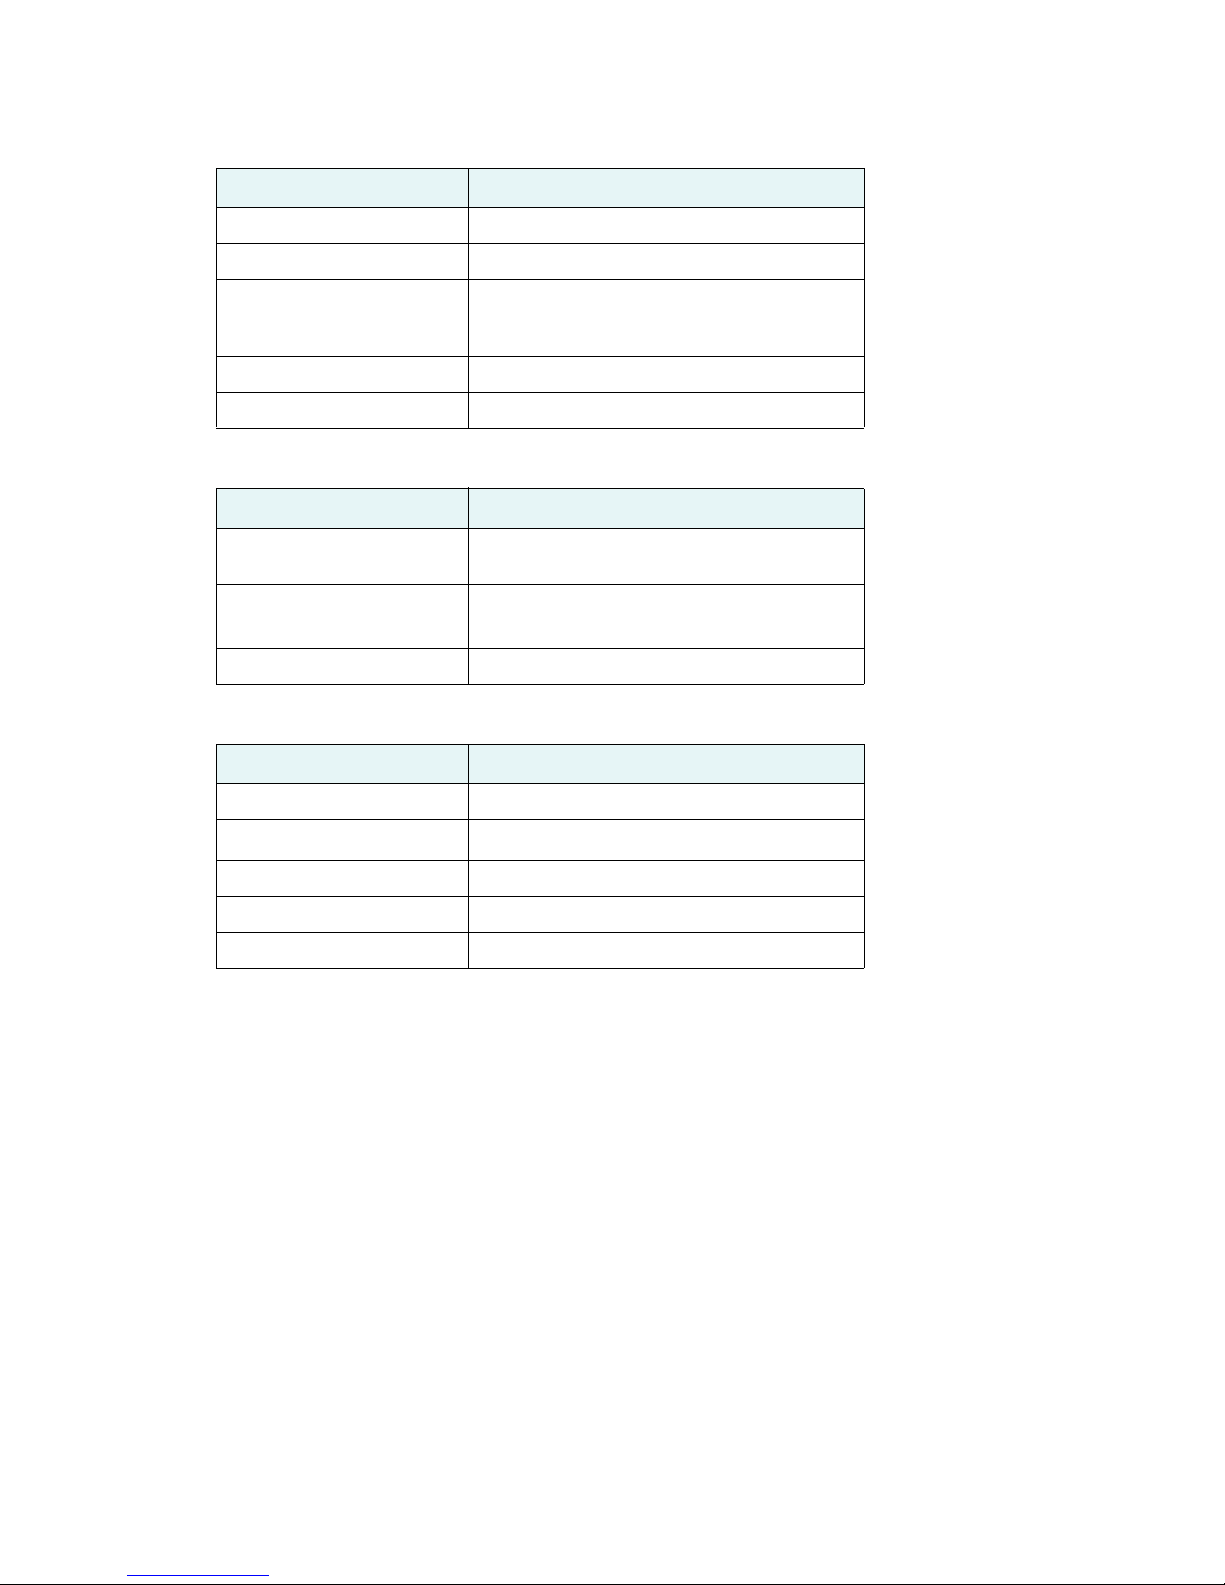
Table B-3: Power specifications
Item Specification
Input voltage 6 to 36 VDC
Power consumption ~ 3 W nominal
Current consumption 320 mA @ 9 VDC
240 mA @ 12 VDC
180 mA @ 16 VDC
Power isolation Isolated to enclosure
Reverse polarity protection Yes
Table B-4: Mechanical specifications
Item Specification
Vector G1 User Guide
Enclosure UV resistant, white plastic, AES HW 600G, non-corrosive,
Dimensions
(not including mounts)
Weight ~ 1.50 kg (3.3 lb)
Table B-5: Environmental specifications
Item Specification
Operating temperature -30°C to +70°C (-22°F to +158°F)
Storage temperature
Humidity 100% non-condensing
Vibration IEC 60945
EMC FCC Part 15, Subpart B; CISPR22; IEC 60945 (CE)
1
Depends on multipath environment, number of satellites in view, satellite geometry, ionospheric activity,
self extinguishing
41.7 L x 15.8 W x 6.9 H (cm)
16.4 L x 6.2 W x 2.7 H (in)
°C to +85°C (-40°F to +185°F)
-40
and use of SBAS
2
Depends on multipath environment, number of satellites in view, satellite geometry, and ionospheric
activity
4
IEC 60945 Standard
5
Based on a 40 second time constant
40
44
Page 47
Appendix C: Using Vector G1 with NMEA 2000 Commands
42
45
Page 48
46
Page 49
Appendix C: Using Vector G1 with NMEA 2000 Commands
NMEA 2000 cable with pinouts – we supply the cable
NMEA 2000 Messages
Table C-1 describes the NMEA 2000 messages.
Table C-1: NMEA 2000 Messages
PG Number
(PGN)
059392 ISO Acknowledgement – Used to
059904 ISO Request – Request the
060928 ISO Address Claim – Used to
126996 Product Information – NMEA 2000®
Description Level
acknowledge the status of certain
requests addressed to a specific ECU
transmission of a specific PGN,
addressed or broadcast
identify to other ECUs the address
claimed by an ECU
Database Version Supported,
Manufacturer’s Product Code,
NMEA 2000® Certification Level,
Load Equivalency Number, and other
product-specific information
126464 Receive/Transmit PGNs group
function -The Transmit / Receive
PGN List Group type of function
is defined by first field. The
message will be a Transmit or
Receive PGN List group
function.
Default
Update
Rate
B
B
B
B
B
Freq
126992 System Time- The purpose of
this PGN is twofold: To provide a
regular transmission of UTC time
and date. To provide
synchronism for measurement
data.
127250 Vessel Heading - Heading sensor
value with a flag for True or
Magnetic. If the sensor value is
Magnetic, the deviation field can
be used to produce a Magnetic
heading, and the variation field
can be used to correct the
Magnetic heading to produce a
True heading.
127251 Rate of Turn - Rate of Turn is the
rate of change of the Heading.
B
B
B
43
47
Page 50
Table C-1: NMEA 2000 Messages
Vector G1 User Guide
PG Number
(PGN)
Description Level
127257 Attitude -is PGN provides a
single transmission that describes
the position of a vessel relative to
both horizontal and vertical
planes. This would typically be
used for vessel stabilization,
vessel control and onboard
platform stabilization.
127258 Magnetic Variation - Message for
transmitting variation. The
message contains a sequence
number to allow synchronization
of other messages such as
Heading or Course over Ground.
The quality of service and age of
service are provided to enable
recipients to determine an
appropriate level of service if
multiple transmissions exist.
128259 Speed - The purpose of this PGN
is to provide a single
transmission that describes the
motion of a vessel.
Default
Update
Rate
Freq
B
B
129025 Position, Rapid Update - This
PGN provides latitude and
longitude referenced to WGS84.
Being defined as single frame
message, as opposed to other
PGNs that include latitude and
longitude and are defined as fast
or multi-packet, this PGN lends
itself to being transmitted more
frequently without using up
excessive bandwidth on the bus
for the benefit of receiving
equipment that may require rapid
position updates.
129026 COG & SOG, Rapid Update -
This PGN is a single frame PGN
that provides Course Over
Ground (COG) and Speed Over
Ground (SOG).
B
B
44
48
Page 51
Appendix C: Using Vector G1 with NMEA 2000 Commands
Table C-1: NMEA 2000 Messages
PG Number
(PGN)
Description Level
129027 Position Delta, High Precision
Rapid Update- The "Position
Delta, High Precision Rapid
Update" Parameter Group is
intended for applications where
very high precision and very fast
update rates are needed for
position data. This PGN can
provide delta position changes
down to 1 millimeter with a delta
time period accurate to 5
milliseconds.
129028 Altitude Delta, High Precision
Rapid Update - The "Altitude
Delta, High Precision Rapid
Update" Parameter Group is
intended for applications where
very high precision and very fast
update rates are needed for
altitude and course over ground
data. This PG can provide delta
altitude changes down to 1
millimeter, a change in direction
as small as 0.0057 degrees, and
with a delta time period accurate
to 5 milliseconds.
Default
Update
Rate
Freq
B
B
129029 GNSS Position Data- This PGN
conveys a comprehensive set of
Global Navigation Satellite
System (GNSS) parameters,
including position information.
129033 Time & Date - This PGN has a
single transmission that provides:
UTC time, UTC Date and Local
Offset.
129538 GNSS Control Status - GNSS
common satellite receiver
parameter status.
129539 GNSS DOPs - This PGN
provides a single transmission
containing GNSS status and
dilution of precision components
(DOP) that indicate the
contribution of satellite geometry
to the overall positioning error.
There are three DOP parameters
reported, horizontal (HDOP),
Vertical (VDOP) and time
(TDOP).
B
B
B
B
45
49
Page 52
Table C-1: NMEA 2000 Messages
Vector G1 User Guide
PG Number
(PGN)
Description Level
129540 GNSS Sats in View - GNSS
information on current satellites
in view tagged by sequence ID.
Information includes PRN,
elevation, azimuth, SNR, defines
the number of satellites; defines
the satellite number and the
information.
129550 GNSS Differential Correction
Receiver Interface - GNSS
common differential correction
receiver parameter status.
129551 GNSS Differential Correction
Receiver Signal - GNSS
differential correction receiver
status tagged by sequence ID.
Status information includes
frequency, SNR, and use as a
correction source.
129545 GNSS RAIM Output - This PGN
is used to provide the output from
a GNSS Receiver's Receiver
Autonomous Integrity
Monitoring (RAIM) process. The
Integrity field value is based
upon the parameters set in PGN
130059 GNS RAIM Settings.
Default
Update
Rate
Freq
B
B
B
B
129546 GNSS RAIM Settings - This
PGN is used to report the control
parameters for a GNSS Receiver
Autonomous Integrity
Monitoring (RAIM) process.
130578 Vessel Speed Components - This
PGN provides a single
transmission that accurately
describes the speed of a vessel by
component vectors.
B
46
50
Page 53
Appendix D: Interfacing to ComNav Autopilot and Compass
Display
48
51
Page 54
52
Page 55
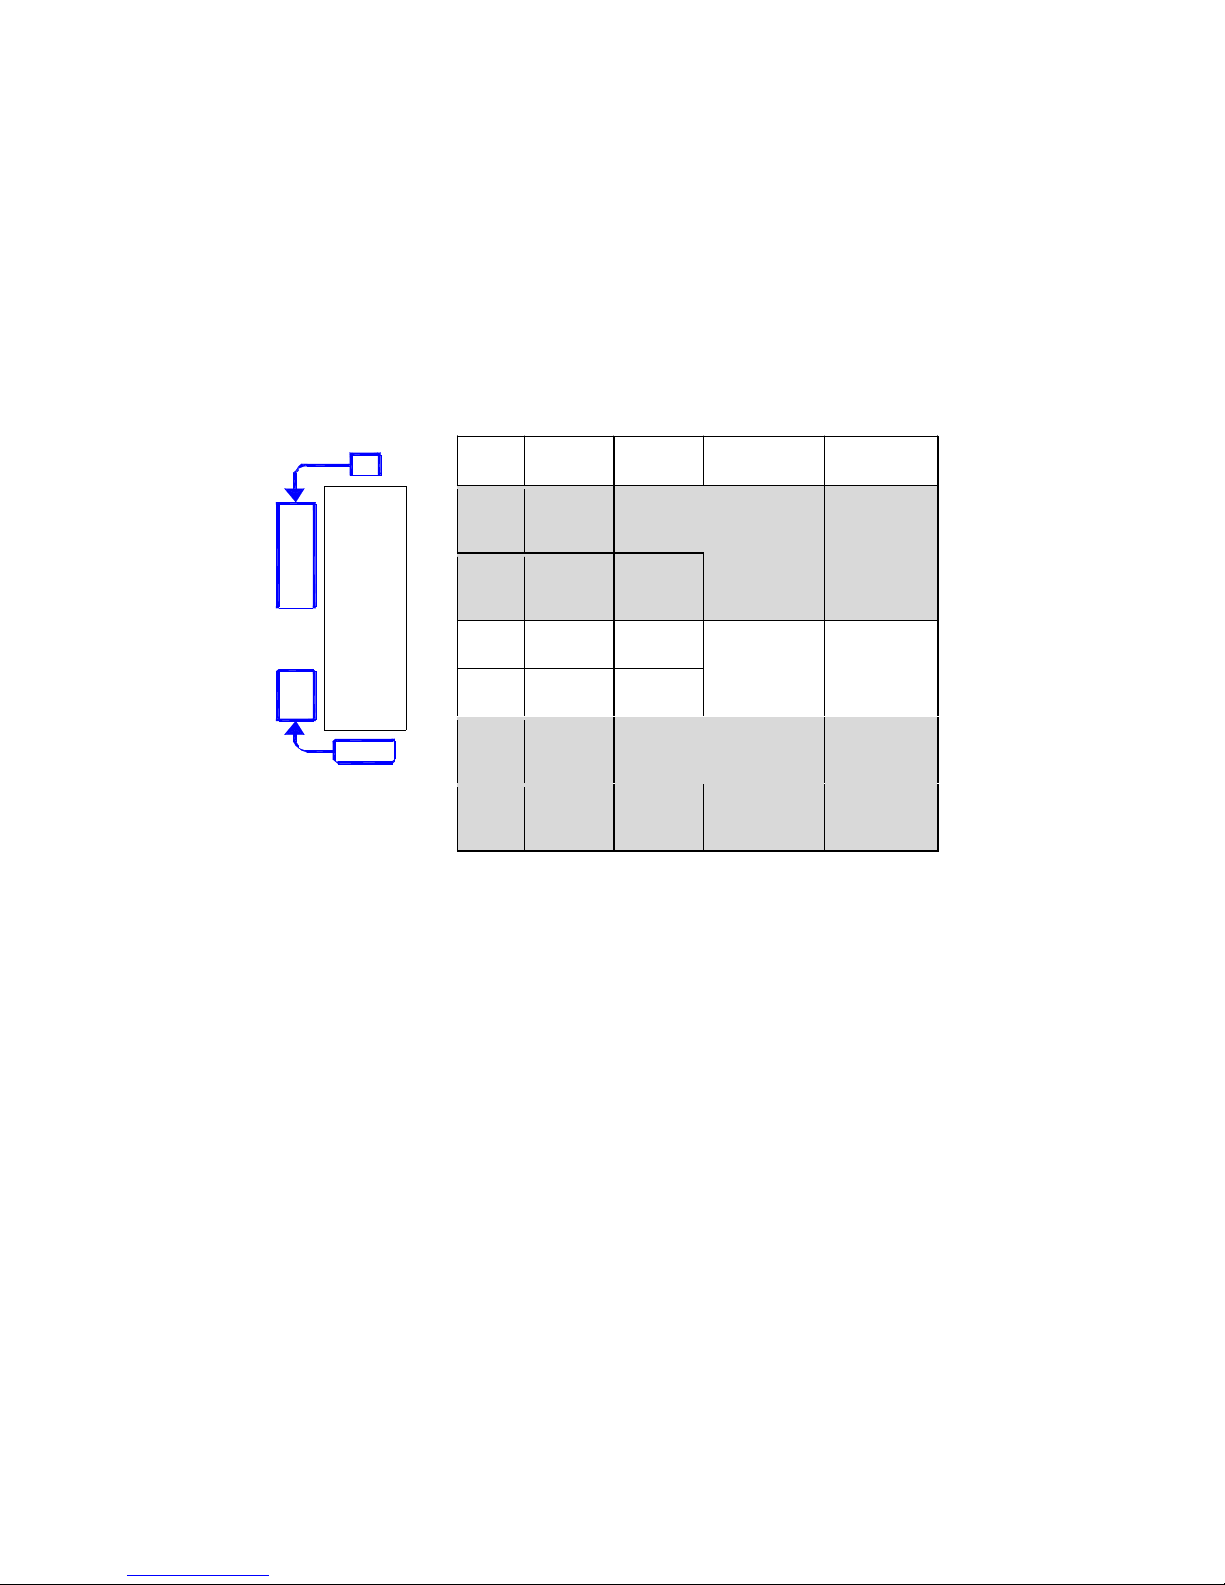
Appendix D: Interfacing to ComNav Autopilot and Compass Display
J9
Pin
Wi re
Col or
Signal Signal
Data
Carried
IN2B
use rsupplied
M
RS-422,
’B’
IN2A
use rsupplied
M
RS-422,
‘A’
from
Chartplotter,
etc.
Navigation:
Waypoints,
Position,
etc .
IN1B
Yellow
Po r t C,
Tx
IN1A
White
Signal
ground
from G 1,
Port B
Transm it
Heading,
Speed
OUT1A
use rsupplied
M
RS-422,
‘A’
OUT1B
use rsupplied
M
RS-422,
’B’
to
Chartplotter,
etc.
Autopilot
status
J9
IN
2A
2B
CH
1A
1B
OUT
N A V I/O
GD
B
A
Commander P2 or Admiral P3 and Navigation G2
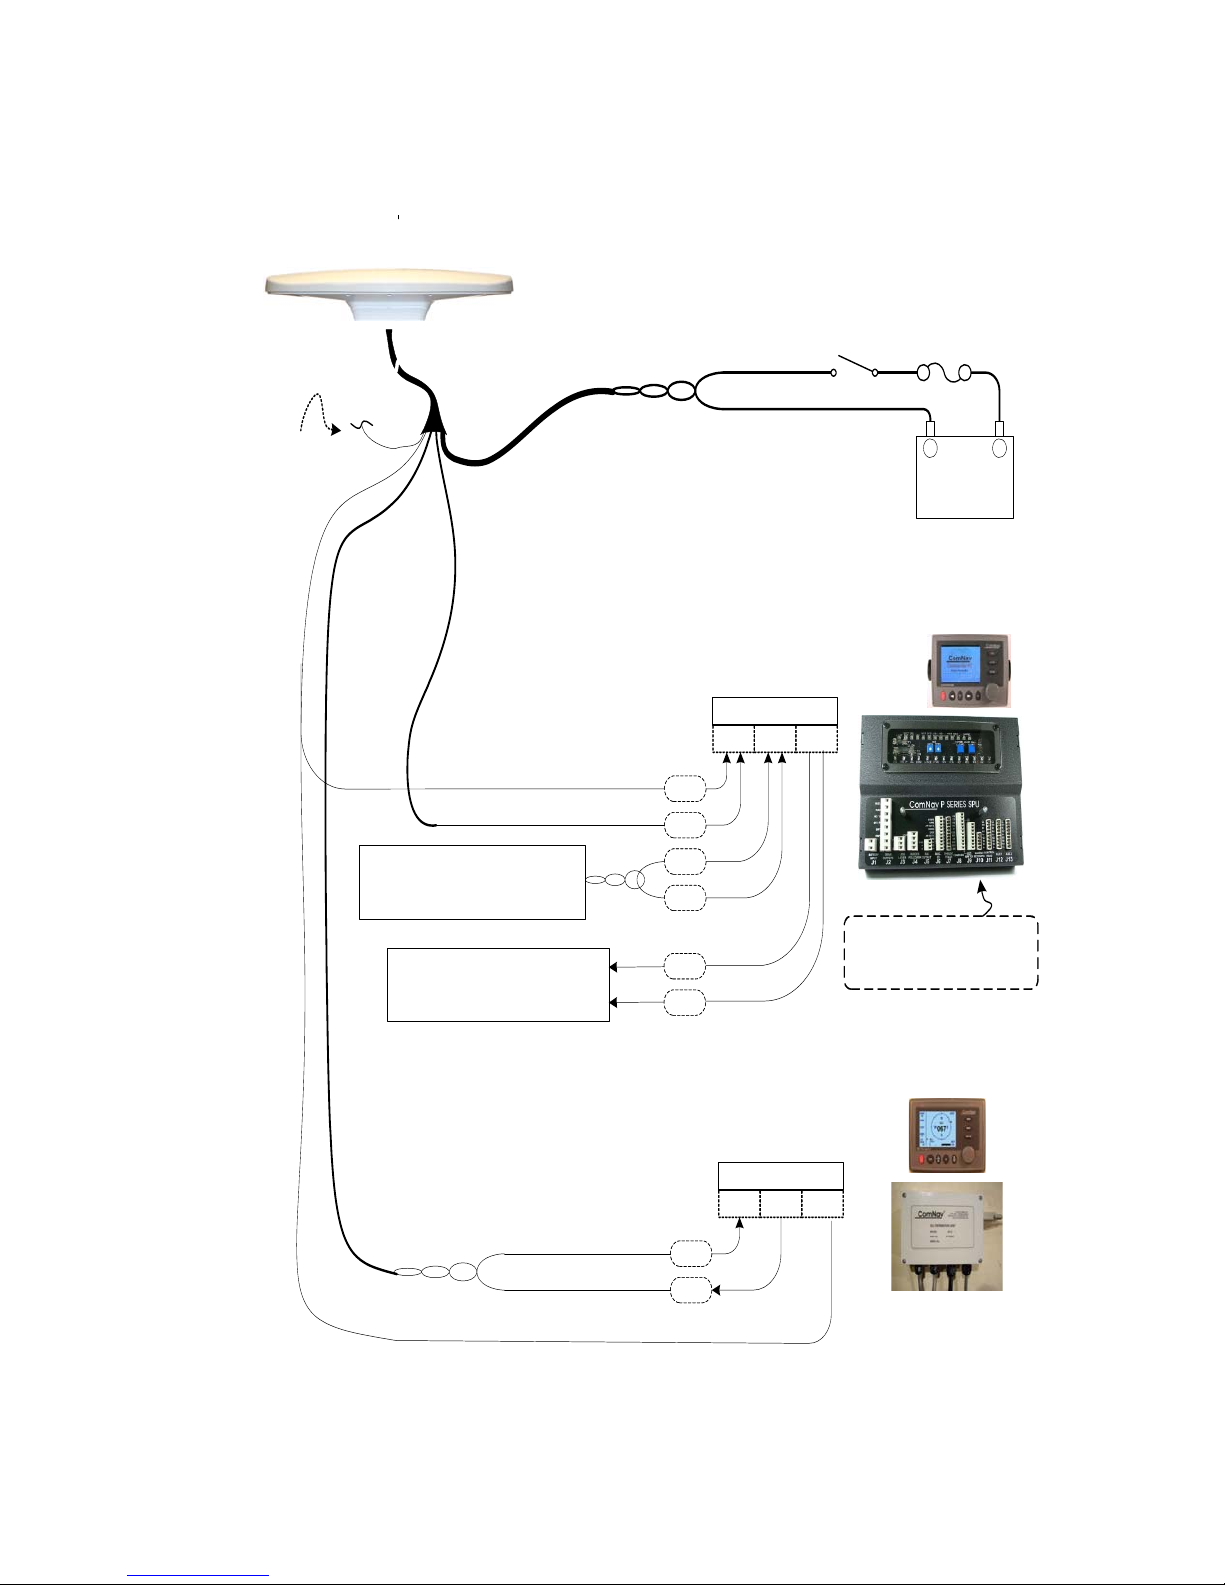
Figure 1 shows the typical connections used with a ComNav Commander P2 Autopilot System (an Admiral
P3 would be wired identically), a Navigator G2 GPS Compass Display System, and a generic Chartplotter or
other type of Navigation System.
Note: this wiring information assumes that the G1 is in its factory-default
configuration: Autopilot data on Port C, and General Navigation data on Port A.
The wiring from G1 to Commander P2 and Admiral P3, SPU J9 - NAV I/O connector, is as follows
:
In addition to the above wiring, the Commander P2 must be configured to look for both heading and speed
data from its NAV1 input port, and for Navigation data from NAV2; for details, see the respective Source
selection descriptions for the Standby, Auto & Nav menus, in the P2 Installation & Operation manual.
Other ComNav Autopilot Systems
All other ComNav autopilots require the use of an optional Sine-Cosine Interface Box (PN 21010004), with
matching interface cable (PN 31110023 or 31110051), to use them with a Vector G1.
See the instructions included with the Sine-Cosine Box for wiring and setup information. Note that the G1's
Port C Tx and the signal ground wires are the ones to be connected to the Convertor.
Table 3 - Commander P2 Connection Detail
53
49
Page 56
Autopi lot Syst em
(Commander P2 shown)
NMEA 01 83
In- 2 OutIn- 1
PORT C
YELLOW Si gnal Gr ound
WHI T E
To Navi gati on Syst em Cont rol ler
&/or ot her NMEA equipment
Heading Source : NAV I N1
Speed Sourc e : NAV IN1
Navigat ion Source : NAV IN2
YELLOW
Signal Ground
Port A (RS-232)
BLUE
BLACK w/ BLUE STRI PE
RS- 23 2
Tx GndRx
GPS Compass Display Syst em
(Navi gator G2 shown)
RED ( 18 A WG)
Fuse
or Breaker
Power
Swi t c h
BLACK ( 18 AWG)
Ship’ s
Bat t er y
11 – 36 VDC
+
-
Cut off & tape back
Shiel d Dra in &
gre en wi re
B
A
Tx
Rx
B
A
B
A
Vector G1
From Navi gati on Syst em
&/or ot her NMEA equipment
Vector G1 User Guide
Figure 1 - Typical Wiring Diagram of a Vector G1 System with Autopilot & Compass Display
54
50
Page 57
Appendix D: Interfacing to ComNav Autopilot and Compass Display
YELLOW
Signal Ground
Por t A ( RS- 23 2 )
BLUE
BROWN
PC for Vector G1 Control & Display
(usi ng Pocket MAX P C or Hyp e r T e r minal )
Tx
Rx
D-Type 9 pi n
Female Connector
(us er -s uppl i ed)
Tx
Rx 2
3
5
PC COM Po r t
Signal & Pin #
Vect or G1
Interfacing to a PC
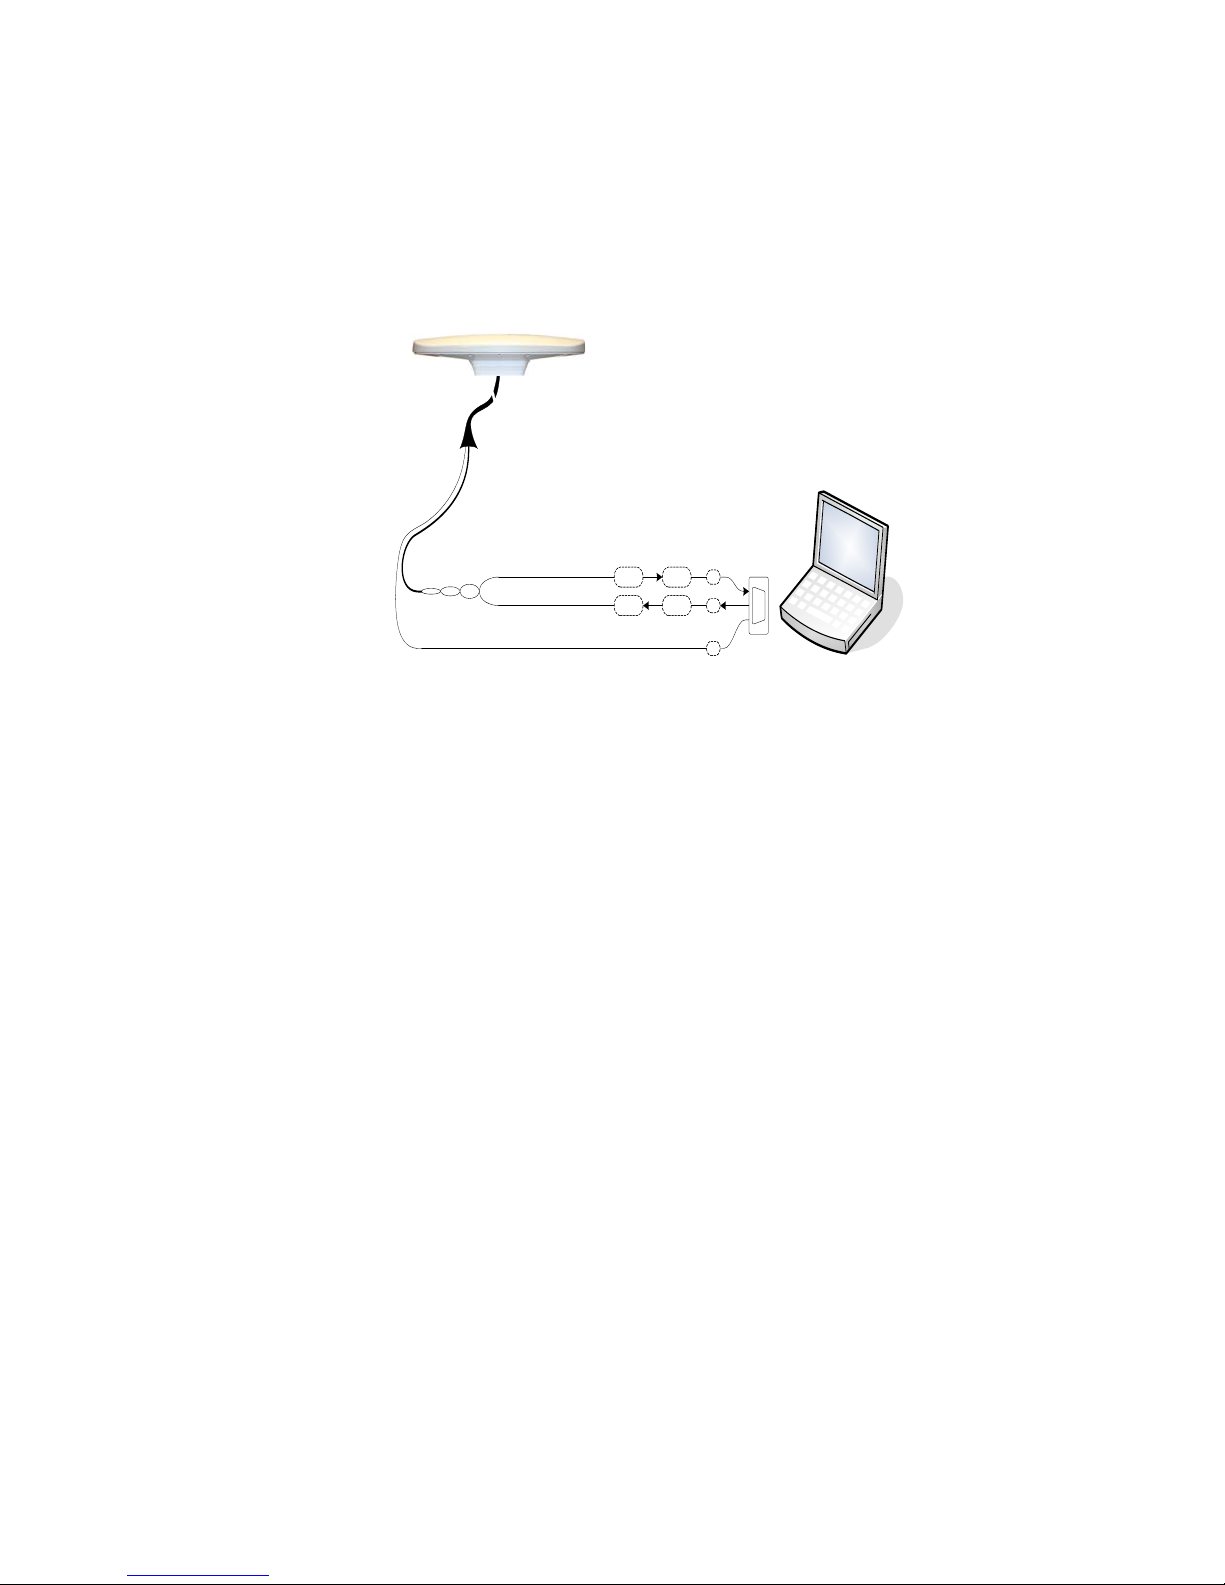
Figure 2 shows the typical connections when using a PC to perform "Navigation display &/or control"
functions or to use the PocketMax3 to configure the G1.
Figure 2 - Typical Wiring with a PC for Vector G1 Control & Display
Interfacing to other NMEA 0183 devices
Many NMEA 0183 devices can accept RS 232 input signal. For these devices, you can connect the G1 RS
232 Rx of Port A or Port C to NMEA 0183 "A" and the G1 signal ground to NMEA 0183 "B". However,
there are devices that only accept RS 422 signal. In such situation, a standard RS 232 RS 422 Convertor
can be used to interface the G1 to an NMEA 0183 devices.
51
55
Page 58
56
Page 59
End User License Agreement
IMPORTANT - This is an agreement (the "Agreement") between you, the end purchaser ("Licensee") and ComNav Marine Ltd.
("ComNav") which permits Licensee to use the ComNav software (the "Software") that accompanies this Agreement. This Software
may be licensed on a standalone basis or may be embedded in a Product. Please read and ensure that you understand this Agreement
before installing or using the Software Update or using a Product.
In this agreement any product that has Software embedded in it at the time of sale to the Licensee shall be referred to as a "Product". As
well, in this Agreement, the use of a Product shall be deemed to be use of the Software which is embedded in the Product.
BY INSTALLING OR USING THE SOFTWARE UPDATE OR THE PRODUCT, LICENSEE THEREBY AGREES TO BE
LEGALLY BOUND BY THE TERMS OF THIS AGREEMENT. IF YOU DO NOT AGREE TO THESE TERMS, (I) DO NOT
INSTALL OR USE THE SOFTWARE, AND (II) IF YOU ARE INSTALLING AN UPDATE TO THE SOFTWARE, DO NOT
INSTALL THE UPDATE AND PROMPTLY DESTROY IT.
COMNAV PROVIDES LIMITED WARRANTIES IN RELATION TO THE SOFTWARE. AS WELL, THOSE WHO USE THE
EMBEDDED SOFTWARE DO SO AT THEIR OWN RISK. YOU SHOULD UNDERSTAND THE IMPORTANCE OF THESE AND
OTHER LIMITATIONS SET OUT IN THIS AGREEMENT BEFORE INSTALLING OR USING THE SOFTWARE OR THE
PRODUCT.
1. LICENSE. ComNav hereby grants to Licensee a non-transferable and non-exclusive license to use the Software as embedded in a
Product and all Updates (collectively the "Software"), solely in binary executable form.
2. RESTRICTIONS ON USE. Licensee agrees that Licensee and its employees will not directly or indirectly, in any manner
whatsoever:
a. install or use more copies of the Software than the number of copies that have been licensed;
b. use or install the Software in connection with any product other than the Product the Software was intended to be used or
installed on as set out in the documentation that accompanies the Software.
c. copy any of the Software or any written materials for any purpose except as part of Licensee's normal backup processes;
d. modify or create derivative works based on the Software;
e. sub-license, rent, lease, loan or distribute the Software;
f. permit any third party to use the Software;
g. use or operate Product for the benefit of any third party in any type of service outsourcing, application service, provider
service or service bureau capacity;
h. reverse engineer, decompile or disassemble the Software or otherwise reduce it to a human perceivable form;
i. Assign this Agreement or sell or otherwise transfer the Software to any other party except as part of the sale or transfer of the
whole Product.
3. UPDATES. At ComNav's discretion ComNav may make Updates available to Licensee. An update ("Update") means any update
to the Software that is made available to Licensee including error corrections, enhancements and other modifications. Licensee
may access, download and install Updates during the Warranty Period only. All Updates that Licensee downloads, installs or uses
shall be deemed to be Software and subject to this Agreement. ComNav reserves the right to modify the Product without any
obligation to notify, supply or install any improvements or alterations to existing Software.
4. SUPPORT. ComNav may make available directly or through its authorized dealers telephone and email support for the Software.
Contact ComNav to find the authorized dealer near you. As well, ComNav may make available user and technical documentation
regarding the Software. ComNav reserves the right to reduce and limit access to such support at any time.
5. BACKUPS AND RECOVERY. Licensee shall back-up all data used, created or stored by the Software on a regular basis as
necessary to enable proper recovery of the data and related systems and processes in the event of a malfunction in the Software or
any loss or corruption of data caused by the Software. Licensee shall assume all risks of loss or damage for any failure to comply
with the foregoing.
6. OWNERSHIP. The Licensee understands that the Licensee does NOT own rights, title and interest in and to the Software and
related materials, including intellectual property rights. The Software is licensed to Licensee, not sold.
7. TRADEMARKS. "ComNav” and the associated logos are trademarks of ComNav. Other trademarks are the property of their
respective owners. Licensee may not use any of these trademarks without the consent of their respective owners.
8. LIMITED WARRANTY. ComNav warrants solely to the Licensee, subject to the exclusions and procedures set forth herein
below, that for a period of one (1) year from the original date of purchase of the Product in which it is embedded (the "Warranty
Period"), the Software, under normal use and maintenance, will conform in all material respects to the documentation provided
with the Software and any media will be free of defects in materials and workmanship. For any Update, ComNav warrants, for 90
days from performance or delivery, or for the balance of the original Warranty Period, whichever is greater, that the Update, under
normal use and maintenance, will conform in all material respects to the documentation provided with the Update and any media
will be free of defects in materials and workmanship. Notwithstanding the foregoing, ComNav does not warrant that the Software
will meet Licensee's requirements or that its operation will be error free.
9. WARRANTY EXCLUSIONS. The warranty set forth in Section (8) will not apply to any deficiencies caused by (a) the Product
not being used as described in the documentation supplied to Licensee, (b) the Software having been altered, modified or
converted in any way by anyone other than ComNav or approved by ComNav, (c) any malfunction of Licensee's equipment or
other software, or (d) damage occurring in transit or due to any accident, abuse, misuse, improper installation, lightning (or other
53
57
Page 60
electrical discharge) or neglect other than that caused by ComNav. ComNav GPS does not warrant or guarantee the precision or
accuracy of positions obtained when using the Software (whether standalone or embedded in a Product). The Product and the
Software is not intended and should not be used as the primary means of navigation or for use in safety of life applications. The
potential positioning and navigation accuracy obtainable with the Software as stated in the Product or Software documentation
serves to provide only an estimate of achievable accuracy based on specifications provided by the US Department of Defense for
GPS positioning and DGPS service provider performance specifications, where applicable.
10. WARRANTY DISCLAIMER. EXCEPT AS EXPRESSLY SET OUT IN THIS AGREEMENT, COMNAV MAKES NO
REPRESENTATION, WARRANTY OR CONDITION OF ANY KIND TO LICENSEE, WHETHER VERBAL OR WRITTEN
AND HEREBY DISCLAIMS ALL REPRESENTATIONS, WARRANTIES AND CONDITIONS OF ANY KIND INCLUDING
FITNESS FOR A PARTICULAR PURPOSE, MERCHANTABILITY, ACCURACY, RELIABILITY OR THAT THE USE OF
THE SOFTWARE WILL BE UNINTERRUPTED OR ERROR-FREE AND HEREBY DISCLAIMS ALL
REPRESENTATIONS, WARRANTIES AND CONDITIONS ARISING AS A RESULT OF CUSTOM, USAGE OR TRADE
AND THOSE ARISING UNDER STATUTE.
11. LIMITS ON WARRANTY DISCLAIMER. Some jurisdictions do not allow the exclusion of implied warranties or conditions,
so some of the above exclusions may not apply to Licensee. In that case, any implied warranties or conditions which would then
otherwise arise will be limited in duration to ninety (90) days from the date of the license of the Software or the purchase of the
Product. The warranties given herein give Licensee specific legal rights and Licensee may have other rights which may vary from
jurisdiction to jurisdiction.
12. CHANGE TO WARRANTY. No employee or agent of ComNav is authorized to change the warranty provided or the limitation
or disclaimer of warranty provisions. All such changes will only be effective if pursuant to a separate agreement signed by senior
officers of the respective parties.
13. WARRANTY CLAIM. In the event Licensee has a warranty claim Licensee must first check for and install all Updates that are
made available. The warranty will not otherwise be honored. Proof of purchase may be required. ComNav does not honor claims
asserted after the end of the Warranty Period.
14. LICENSEE REMEDIES. In all cases which involve a failure of the Software to conform in any material respect to the
documentation during the Warranty Period or a breach of a warranty, ComNav's sole obligation and liability, and Licensee's sole
and exclusive remedy, is for ComNav, at ComNav's option, to (a) repair the Software, (b) replace the Software with software
conforming to the documentation, or (c) if ComNav is unable, on a reasonable commercial basis, to repair the Software or to
replace the Software with conforming software within ninety (90) days, to terminate this Agreement and thereafter Licensee shall
cease using the Software. ComNav will also issue a refund for the price paid by Licensee less an amount on account of
amortization, calculated on a straight-line basis over a deemed useful life of three (3) years.
15. LIMITATION OF LIABILITY. IN NO EVENT WILL COMNAV BE LIABLE TO LICENSEE FOR ANY INCIDENTAL,
CONSEQUENTIAL, SPECIAL OR INDIRECT DAMAGES INCLUDING ARISING IN RELATION TO ANY LOSS OF
DATA, INCOME, REVENUE, GOODWILL OR ANTICIPATED SAVINGS EVEN IF COMNAV HAS BEEN INFORMED OF
THE POSSIBILITY OF SUCH LOSS OR DAMAGE. FURTHER, IN NO EVENT WILL COMNAV'S TOTAL CUMULATIVE
LIABILITY HEREUNDER, FROM ALL CAUSES OF ACTION OF ANY KIND, EXCEED THE TOTAL AMOUNT PAID BY
LICENSEE TO COMNAV TO PURCHASE THE PRODUCT. THIS LIMITATION AND EXCLUSION APPLIES
IRRESPECTIVE OF THE CAUSE OF ACTION, INCLUDING BUT NOT LIMITED TO BREACH OF CONTRACT,
NEGLIGENCE, STRICT LIABILITY, TORT, BREACH OF WARRANTY, MISREPRESENTATION OR ANY OTHER LEGAL
THEORY AND WILL SURVIVE A FUNDAMENTAL BREACH.
16. LIMITS ON LIMITATION OF LIABILITY. Some jurisdictions do not allow for the limitation or exclusion of liability for
incidental or consequential damages, so the above limitation or exclusion may not apply to Licensee and Licensee may also have
other legal rights which may vary from jurisdiction to jurisdiction.
17. BASIS OF BARGAIN. Licensee agrees and acknowledges that ComNav has set its prices and the parties have entered into this
Agreement in reliance on the limited warranties, warranty disclaimers and limitations of liability set forth herein, that the same
reflect an agreed-to allocation of risk between the parties (including the risk that a remedy may fail of its essential purpose and
cause consequential loss), and that the same forms an essential basis of the bargain between the parties. Licensee agrees and
acknowledges that ComNav would not have been able to sell the Product at the amount charged on an economic basis without such
limitations.
18. PROPRIETARY RIGHTS INDEMNITY. ComNav shall indemnify, defend and hold harmless Licensee from and against any
and all actions, claims, demands, proceedings, liabilities, direct damages, judgments, settlements, fines, penalties, costs and
expenses, including royalties and attorneys' fees and related costs, in connection with or arising out of any actual infringement of
any third party patent, copyright or other intellectual property right by the Software or by its use, in accordance with this
Agreement and documentation, PROVIDED THAT: (a) ComNav has the right to assume full control over any action, claim,
demand or proceeding, (b) Licensee shall promptly notify ComNav of any such action, claim, demand, or proceeding, and (c)
Licensee shall give ComNav such reasonable assistance and tangible material as is reasonably available to Licensee for the
defense of the action, claim, demand or proceeding. Licensee shall not settle or compromise any of same for which ComNav has
agreed to assume responsibility without ComNav's prior written consent. Licensee may, at its sole cost and expense, retain separate
counsel from the counsel utilized or retained by ComNav.
19. INFRINGEMENT. If use of the Software may be enjoined due to a claim of infringement by a third party then, at its sole
discretion and expense, ComNav may do one of the following: (a) negotiate a license or other agreement so that the Product is no
longer subject to such a potential claim, (b) modify the Product so that it becomes non-infringing, provided such modification can
54
58
Page 61
be accomplished without materially affecting the performance and functionality of the Product, (c) replace the Software, or the
Product, with non-infringing software, or product, of equal or better performance and quality, or (d) if none of the foregoing can be
done on a commercially reasonable basis, terminate this license and Licensee shall stop using the Product and ComNav shall
refund the price paid by Licensee less an amount on account of amortization, calculated on a straight-line basis over a deemed
useful life of three (3) years.
The foregoing sets out the entire liability of ComNav and the sole obligations of ComNav to Licensee in respect of any claim that
the Software or its use infringes any third party rights.
20. INDEMNIFICATION. Except in relation to an infringement action, Licensee shall indemnify and hold ComNav harmless from
any and all claims, damages, losses, liabilities, costs and expenses (including reasonable fees of lawyers and other professionals)
arising out of or in connection with Licensee's use of the Product, whether direct or indirect, including without limiting the
foregoing, loss of data, loss of profit or business interruption.
21. TERMINATION. Licensee may terminate this Agreement at any time without cause. ComNav may terminate this Agreement on
30 days notice to Licensee if Licensee fails to materially comply with each provision of this Agreement unless such default is
cured within the 30 days. Any such termination by a party shall be in addition to and without prejudice to such rights and remedies
as may be available, including injunction and other equitable remedies. Upon receipt by Licensee of written notice of termination
from ComNav or termination by Licensee, Licensee shall at the end of any notice period (a) cease using the Software; and (b)
return to ComNav (or destroy and provide a certificate of a Senior Officer attesting to such destruction) the Software and all
related material and any magnetic or optical media provided to Licensee. The provisions of Sections 6), 7), 8), 9), 10), 15), 21), 26)
and 27) herein shall survive the expiration or termination of this Agreement for any reason.
22. EXPORT RESTRICTIONS. Licensee agrees that Licensee will comply with all export control legislation of Canada, the United
States, Australia and any other applicable country's laws and regulations, whether under the Arms Export Control Act, the
International Traffic in Arms Regulations, the Export Administration Regulations, the regulations of the United States
Departments of Commerce, State, and Treasury, or otherwise as well as the export control legislation of all other countries.
23. PRODUCT COMPONENTS. The Product may contain third party components. Those third party components may be subject to
additional terms and conditions. Licensee is required to agree to those terms and conditions in order to use the Product.
24. FORCE MAJEURE EVENT. Neither party will have the right to claim damages as a result of the other's inability to perform or
any delay in performance due to unforeseeable circumstances beyond its reasonable control, such as labor disputes, strikes,
lockouts, war, riot, insurrection, epidemic, Internet virus attack, Internet failure, supplier failure, act of God, or governmental
action not the fault of the non-performing party.
25. FORUM FOR DISPUTES. The parties agree that the courts located in Vancouver, BC, Canada and the courts of appeal there
from will have exclusive jurisdiction to resolve any disputes between Licensee and ComNav concerning this Agreement or
Licensee's use or inability to use the Software and the parties hereby irrevocably agree to attorn to the jurisdiction of those courts.
Notwithstanding the foregoing, either party may apply to any court of competent jurisdiction for injunctive relief.
26. APPLICABLE LAW. This Agreement shall be governed by the laws of the Province of British Columbia, Canada, exclusive of
any of its choice of law and conflicts of law jurisprudence.
27. CISG. The United Nations Convention on Contracts for the International Sale of Goods will not apply to this Agreement or any
transaction hereunder.
28. GENERAL. This is the entire agreement between Licensee and ComNav relating to the Product and Licensee's use of the same,
and supersedes all prior, collateral or contemporaneous oral or written representations, warranties or agreements regarding the
same. No amendment to or modification of this Agreement will be binding unless in writing and signed by duly authorized
representatives of the parties. Any and all terms and conditions set out in any correspondence between the parties or set out in a
purchase order which are different from or in addition to the terms and conditions set forth herein, shall have no application and no
written notice of same shall be required. In the event that one or more of the provisions of this Agreement is found to be illegal or
unenforceable, this Agreement shall not be rendered inoperative but the remaining provisions shall continue in full force and
effect.
55
59
Page 62
60
Page 63
Warranty Information
Limited Warranty
This Limited Warranty (the “Warranty”) covers all Vector and Navigator GPS Compass products &
accessories (the “Equipment”) sold by ComNav Marine Ltd. (“ComNav”).
LIMITED ONE YEAR WARRANTY
ComNav warrants to the Purchaser, provided that the recommended installation and maintenance
procedures set forth in the manual (the “Manual”) provided with the Equipment have been followed,
and subject always to the other provisions of this Warranty, that the Equipment is free from defects in
workmanship and materials under normal use and service for a period of one (1) year from the date of
purchase of the Equipment by the Purchaser.
EXCLUSIONS
This Limited Warranty is null and void if:
1. The serial number of the Equipment has been removed, altered or mutilated;
2. Any of the anti-tamper seals covering case-screw holes, or other mechanisms for opening the
Equipment’s case, have been removed, broken or otherwise tampered with;
3. There are any defects in it, or damages to it, caused by:
a. Faulty installation or hook-up of the Equipment;
b. Abuse, misuse, or any use of the Equipment in violation of the instructions set forth in the Manual;
c. Shipping, alterations, or incorrect and/or unauthorized service;
d. Accident, exposure of the Equipment to excessive heat, fire, lightning or other electrical discharge,
or water immersion;
e. Water damage due to failure to fully fasten the plug connected into the equipment’s power/signal
receptacle;
f. Improper or inadequate ancillary or connected equipment.
OTHER LIMITATIONS AND EXCLUSIONS
1. ComNav does not warrant or guarantee the precision or accuracy of positions, heading, or other
GPS-based navigation data obtained when using the Equipment. The potential accuracy of the
Equipment, as stated in the Manual, associated ComNav literature and/or Product specifications,
provides only an estimate of the highest achievable accuracy based on:
a. Specifications provided by the US Department of Defence for GPS Positioning;
b. GPS Receiver specifications provided by the OEM manufacturer;
c. DGPS service provider performance specifications.
2. The Equipment is not intended for primary navigation or for use in safety of life applications;
ComNav does not warrant or guarantee that the Equipment will perform in accordance with the
requirements of such usage;
3. ComNav reserves the right to modify the Equipment without any obligation to notify, supply or
install any improvements or alterations to existing Equipment.
57
61
Page 64
NO OTHER WARRANTIES
THE FOREGOING WARRANTY IS EXCLUSIVE OF ALL OTHER WARRANTIES AND
CONDITIONS, WHETHER WRITTEN, ORAL OR IMPLIED, ARISING BY STATUTE OR
OTHERWISE, WITH RESPECT TO THE DESIGN, SALE, INSTALLATION OR USE OF THE
EQUIPMENT, INCLUDING BUT NOT LIMITED TO IMPLIED WARRANTIES OR
CONDITIONS OF MERCHANTABILITY AND FITNESS FOR THE ORDINARY PURPOSES
FOR WHICH THE EQUIPMENT IS USED OR FITNESS FOR A PARTICULAR PURPOSE, AND
ANY OTHER OBLIGATIONS ON THE PART OF COMNAV, ITS EMPLOYEES, SUPPLIERS,
AGENTS, OR REPRESENTATIVES.
LIMITATION OF LIABILITY
The extent of ComNav’s liability for damages of any nature to the end purchaser or any other person
or entity whether in contract or tort, and whether to persons or property, shall in no case exceed, in the
aggregate, the cost of correcting the defect in the equipment or, at ComNav’s option, the cost of
replacing the defective item. In no event will ComNav be liable for any loss of production, loss of
profits, loss of use or for any special, indirect, incidental, consequential or contingent damages, even
if ComNav has been advised of the possibility of such damages. Without limiting the foregoing,
ComNav shall not be liable for any damages of any kind resulting from installation, use, quality,
performance or accuracy of the equipment.
NOTICE OF DEFECT
The Limited Warranty will not apply with respect to any defective Equipment unless written notice of
such defect is given to ComNav, by mail to the address for ComNav set forth below, or by facsimile
to ComNav at 604-207-8008, and unless that written notice is received by ComNav within ten (10)
days of the date upon which the defect first became known to the Purchaser.
Notices sent by mail from within North America will be deemed to be received by ComNav on the
seventh (7th) day first following the date of posting. Notices sent by mail from anywhere else in the
world will be deemed to be received by ComNav on the tenth (10th) day next following the date of
posting. Notices sent by facsimile will be deemed to be received by ComNav on the date of
transmission with appropriate answerback confirmation.
REMEDIES NOT TRANSFERABLE
The Purchaser’s remedies under this Warranty apply only to the original end-user of the ComNav
Equipment, being the Purchaser, and apply only to the original installation of the Equipment. The
Purchaser’s remedies under this Warranty are not transferable or assignable by the Purchaser to
others in whole or in part.
CUSTOMER REMEDIES
1. If the Equipment, or any part thereof, proves to be defective within the warranty period, the
Purchaser shall do the following:
a. contact ComNav, by phoning 604-207-1600, to discuss the nature of the problem and to obtain
return shipping instructions for the defective Equipment;and,
b. prepare a detailed written statement of the nature and circumstances of the defect, to the best of the
Purchaser’s knowledge, and including the date of purchase of the Equipment, the place of
purchase, the name and address of the installer, and the Purchaser’s name, address and telephone
58
62
Page 65
number, all to be sent, along with proof of purchase, to ComNav at the address set out below, and
within the time limits set out above for Notice of Defect.
2. If, upon examination by ComNav, the defect is determined to result from defective workmanship
or material and if the defect has occurred within the warranty period set forth above, the Equipment
or the defective parts thereof shall be repaired or replaced, at ComNav’s sole option, without
charge, and shall be returned to the Purchaser at ComNav’s expense. Return delivery will be by the
most economical means. Should the Purchaser require that the Equipment be returned by a faster
method, the costs incurred by the faster delivery will be pre-paid by the Purchaser.
3. No refund of the purchase price for the Equipment will be made to the Purchaser unless ComNav is
unable to remedy the defect after having a reasonable number of opportunities to do so.
4. Warranty service shall be performed only by ComNav. Any attempts to remedy the defect by
anyone else shall render the warranties set forth in this Warranty null and void.
CHOICE OF LAW AND JURISDICTION
This Warranty is governed by the laws of the Province of British Columbia, Canada. If the Purchaser
acquired the Equipment outside of Canada, each of the parties hereto irrevocably attorn to the
jurisdiction of the courts of the Province of British Columbia, Canada, and further agree to settle any
dispute, controversy or claim arising out of or relating to this Limited Warranty, or the breach,
termination, or invalidity of it, by arbitration under the rules of the British Columbia International
Commercial Arbitration Centre (“BCICAC”). The appointing authority shall be BCICAC [or, if the
BCICAC shall cease to exist, the Chief Justice of the Supreme Court of British Columbia]. BCICAC
shall administer the case in accordance with BCICAC Rules. There shall be one arbitrator and the
place of arbitration shall be Vancouver, British Columbia, Canada.
The United Nations Convention on Contracts for the International Sale of Goods Act, S.B.C 1990, c.
20, and any other statutory enactments of the United Nations Convention on Contracts for the
International Sale of Goods do not apply to this Warranty.
ComNav Maine Ltd.
#15 - 13511 Crestwood Place
Richmond, British Columbia
V6V 2G1
Canada
www.comnav.com
WARNING
The Equipment is an aid to navigation only. It is not intended or designed to replace the person on
watch. A qualified person should always be in a position to monitor the vessel’s heading, and to
watch for navigational hazards, and should be prepared to revert to manual steering immediately if an
undesired change of heading occurs, if the heading is not maintained within reasonable limits, or
when navigating in a hazardous situation.
ALWAYS REMEMBER:
WHENEVER UNDER WAY, A QUALIFIED PERSON ON WATCH IS REQUIRED BY LAW.
: :
59
63
 Loading...