

Page 1
TF03 UART/CAN User Manual
INTRODUCTION
Page1 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
TF03 UART/CAN
Long-distance Single-point LiDAR
User Manual
Page 2
TF03 UART/CAN User Manual
INTRODUCTION
Page2 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
Described Product
Long-range single-point LiDAR: TF03 UART/CAN
Manufacturer
Benewake (Beijing) Co., Ltd.
NO.28 Xinxi Road
Haidian District
Beijing, PRC
Legal information
This work is protected by copyright. Any rights derived from the copyright shall be reserved for
Benewake (Beijing). Reproduction of this document or parts of this document is only
permissible within the limits of the legal determination of Copyright Law. Any modification,
abridgment or translation of this document is prohibited without the express written permission
of Benewake (Beijing).
The trademarks stated in this document are the property of their respective owner.
© Benewake (Beijing). All rights reserved.
Original document
This document is an original document of Benewake (Beijing).
Page 3
TF03 UART/CAN User Manual
INTRODUCTION
Page3 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
TABLE OF CONTENTS
1 INTRODUCTION .......................................................................................................................... 5
1.1 FAILURE SCENARIOS ............................................................................................................................ 5
1.2 SYMBOLS AND DOCUMENT CONVENTIONS ............................................................................................... 6
2 PRODUCT DESCRIPTION ............................................................................................................. 7
2.1 APPEARANCE OVERVIEW ..................................................................................................................... 7
2.2 DIMENSIONAL DRAWING ..................................................................................................................... 7
2.3 MEASURING PRINCIPLE........................................................................................................................ 8
2.4 TECHNICAL SPECIFICATION .................................................................................................................... 8
2.5 FOV .............................................................................................................................................. 10
3 ELECTRICAL INSTALLATION ....................................................................................................... 11
3.1 PIN AND WIRE COLOR ASSIGNMENT ..................................................................................................... 11
3.2 CONNECTOR ........................................................................................................ 错误!未定义书签。
3.3 WIRE CROSS-SECTIONS ...................................................................................................................... 11
3.4 GENERAL CONDITIONS FOR DATA INTERFACE .......................................................................................... 12
3.5 WIRING THE UART INTERFACE ........................................................................................................... 12
3.6 WIRING THE CAN INTERFACE ............................................................................................................. 13
3.7 CAN BUS ....................................................................................................................................... 13
4 COMMUNICATION PROTOCOLS................................................................................................ 15
4.1 COMMUNICATION PROTOCOL OF UART ................................................................................................ 15
4.2 USER PROTOCOL OF UART ................................................................................................................. 15
4.3 COMMUNICATION PROTOCOL OF CAN.................................................................................................. 16
4.4 USER PROTOCOL OF CAN ................................................................................................................... 16
5 CUSTOM CONFIGURATION ....................................................................................................... 16
5.1 COMMAND PROTOCOL ...................................................................................................................... 16
Page 4
TF03 UART/CAN User Manual
INTRODUCTION
Page4 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
5.2 COMMON COMMANDS ..................................................................................................................... 17
5.3 COMMAND EDITING.......................................................................................................................... 18
6 OPTIONAL ACCESSORIES .......................................................................................................... 19
6.1 SELF-CLEANING MODULE.................................................................................................................... 19
6.2 AIMING BEAM MODULE ..................................................................................................................... 21
6.3 EXTENSION CORD ............................................................................................................................. 21
7 QUICK START GUIDE ................................................................................................................. 22
7.1 CONNECTION AND BASIC TEST ............................................................................................................. 22
7.2 TROUBLESHOOTING GUIDE FOR INITIAL TEST .......................................................................................... 23
7.3 WORKING MODE.............................................................................................................................. 24
7.4 INFLUENCES OF OBJECT SURFACES ON THE MEASUREMENT ........................................................................ 24
8 TROUBLESHOOTING ................................................................................................................. 27
ATTACHMENT 1: REFLECTIVITY OF DIFFERENT MATERIALS ............................................................ 29
Page 5
TF03 UART/CAN User Manual
INTRODUCTION
Page5 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
1 INTRODUCTION
The User Manual provide important information on how to use TF03. It contains the basic
information about TF03 and describes how to set up and configure the interfaces.
The User Manual contains detailed information about the interfaces including syntax and
available functionality. It focuses on TF03 specific topics and does not describe the basic
technology behind each interface.
The details of the result output formatting and the contents and syntax of the command
channels are shared by several interfaces. They are described in an appendix valid for all
relevant interfaces.
1.1 Failure scenarios
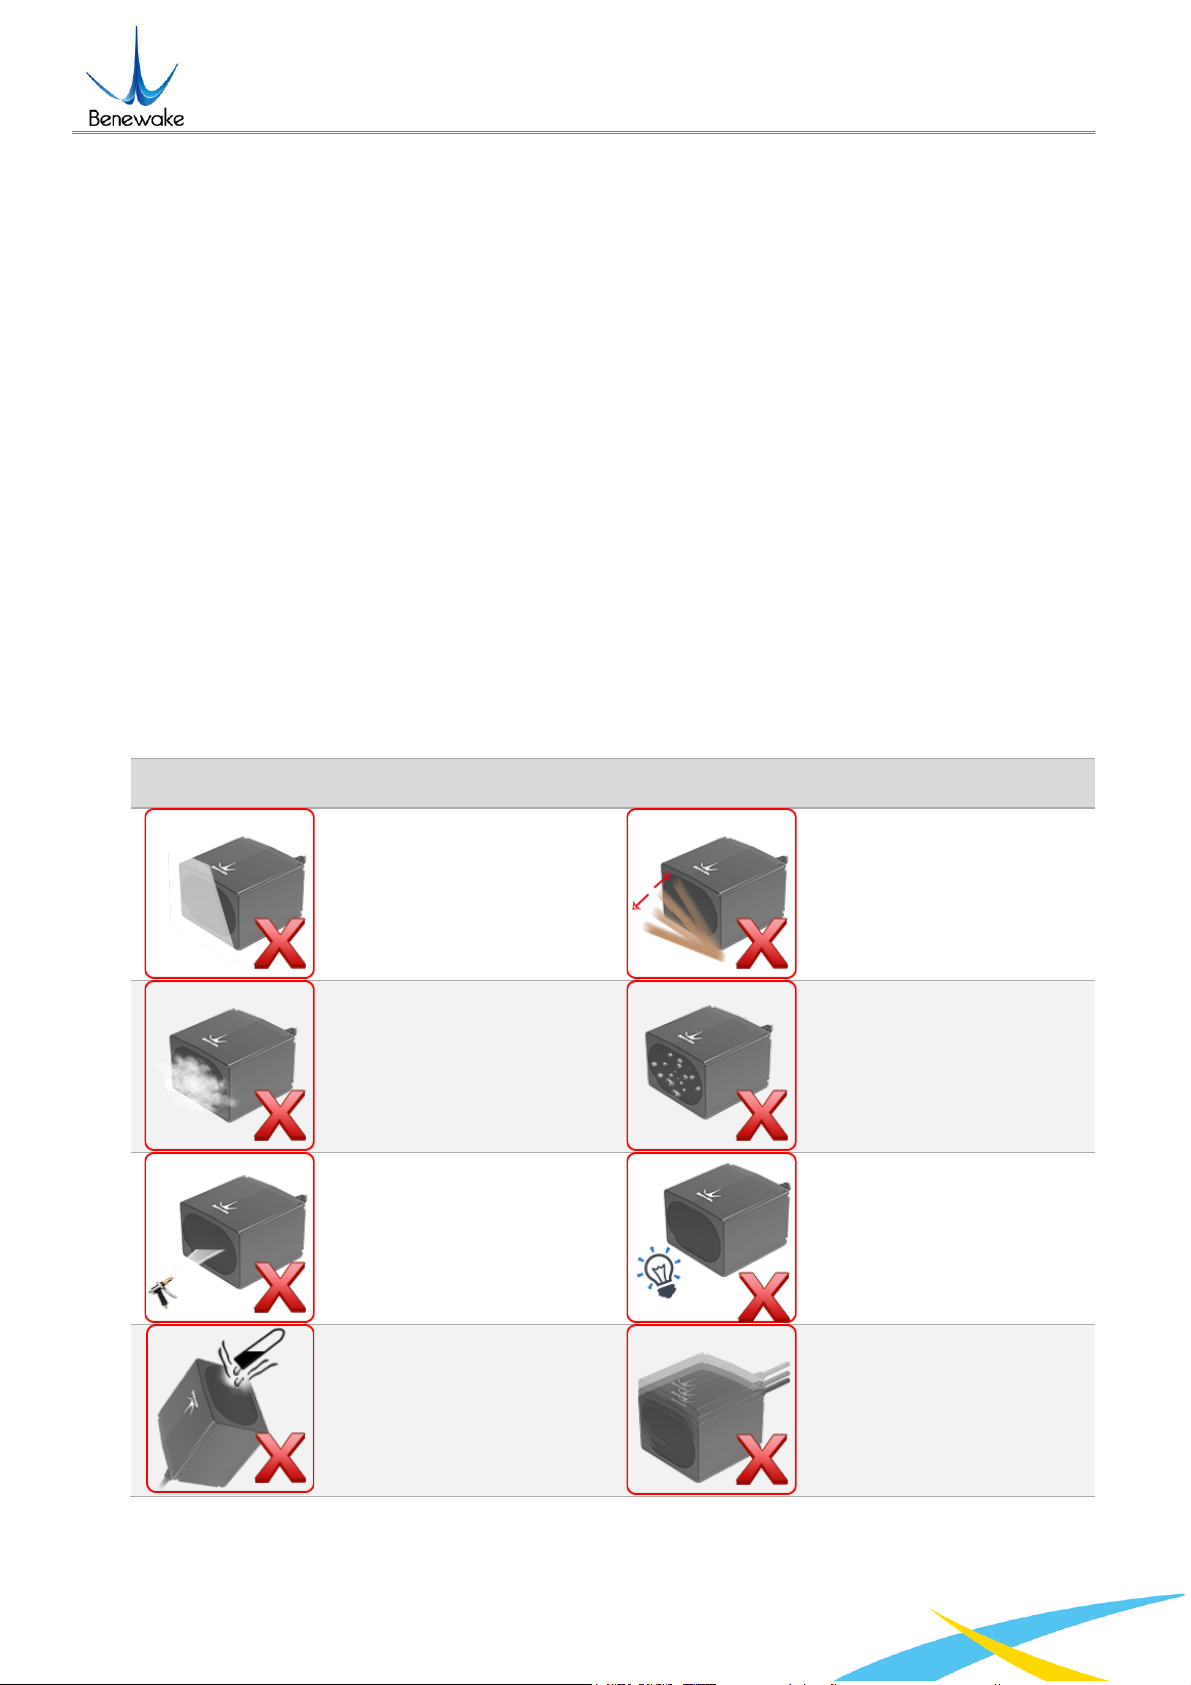
As a precision optical distance sensor, TF03’s performance is greatly affected by
environment. Certain scenarios will even damage TF03. Each of these failure scenarios
have been tested in real field tests.
Table 1 Failure scenarios of TF03
Scenario
Description
Scenario
Description
Do not cover the laser
window.
Avoid moving objects in the
detection field.
Avoid the presence of
heavy smoke, fog and rain
in the detection field.
Avoid condensation.
Avoid direct exposure to
high pressure cleaning.
Avoid exposure to strong
light source with same
wavelength.
Do not exposure to
corrosive liquids.
Avoid extreme vibrations.
Page 6
TF03 UART/CAN User Manual
INTRODUCTION
Page6 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
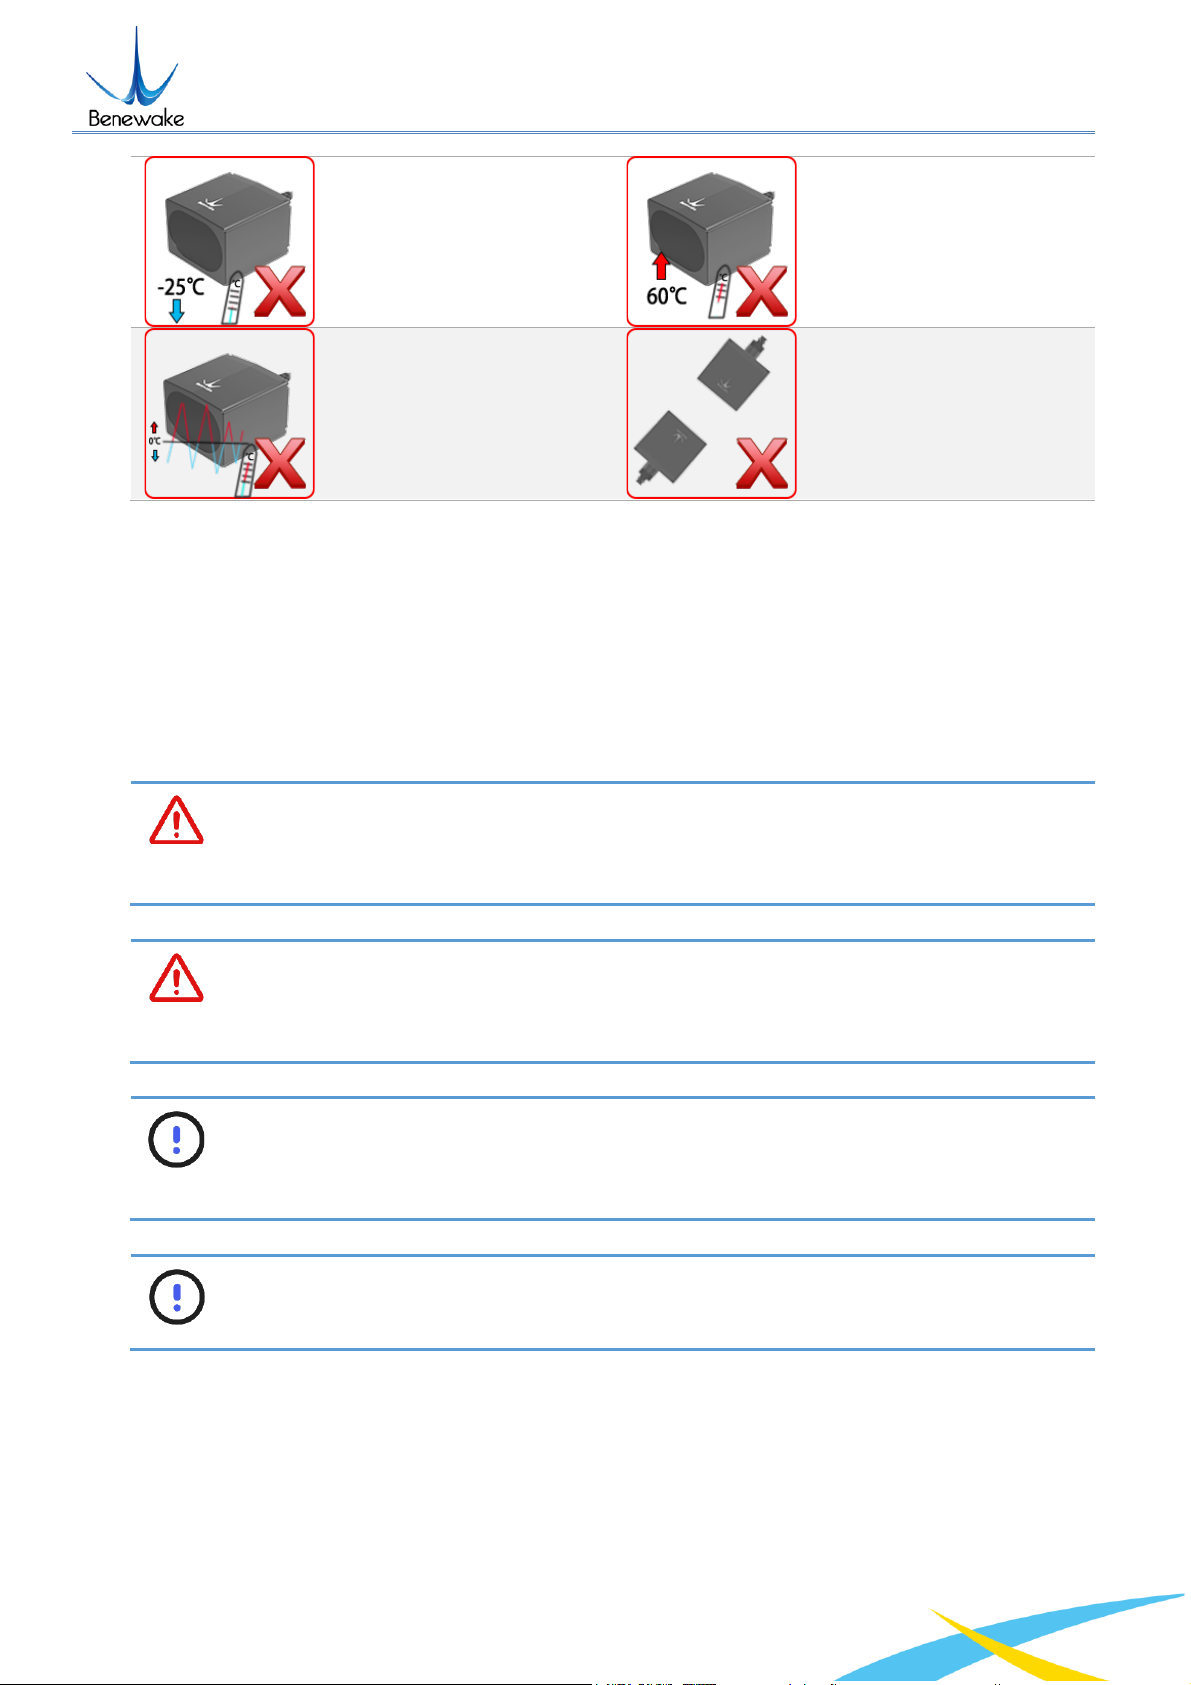
Do not use in extremely low
temperature environments.
Do not use in extremely
high temperature
environments.
Avoid exposure to sudden
and extreme temperature
changes.
Avoid direct exposure to
another LiDAR with same
wavelength.
1.2 Symbols and document conventions
Warnings and important information in this document are labeled with symbols. The
warnings are introduced by signal words that indicate the extent of the danger. These
warnings must be observed at all times and care must be taken to avoid accidents,
personal injury, and material damage.
The following symbols and conventions are used in this document:
WARNING
Indicates a situation presenting possible danger, which may lead to death or
serious injuries if not prevented.
CAUTION
Indicates a situation presenting possible danger, which may lead to moderate or
minor injuries if not prevented.
NOTICE
Indicates a situation presenting possible danger, which may lead to property
damage if not prevented.
NOTE
Indicates useful tips and recommendations.
Page 7
TF03 UART/CAN User Manual
PRODUCT DESCRIPTION
Page7 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
2 PRODUCT DESCRIPTION
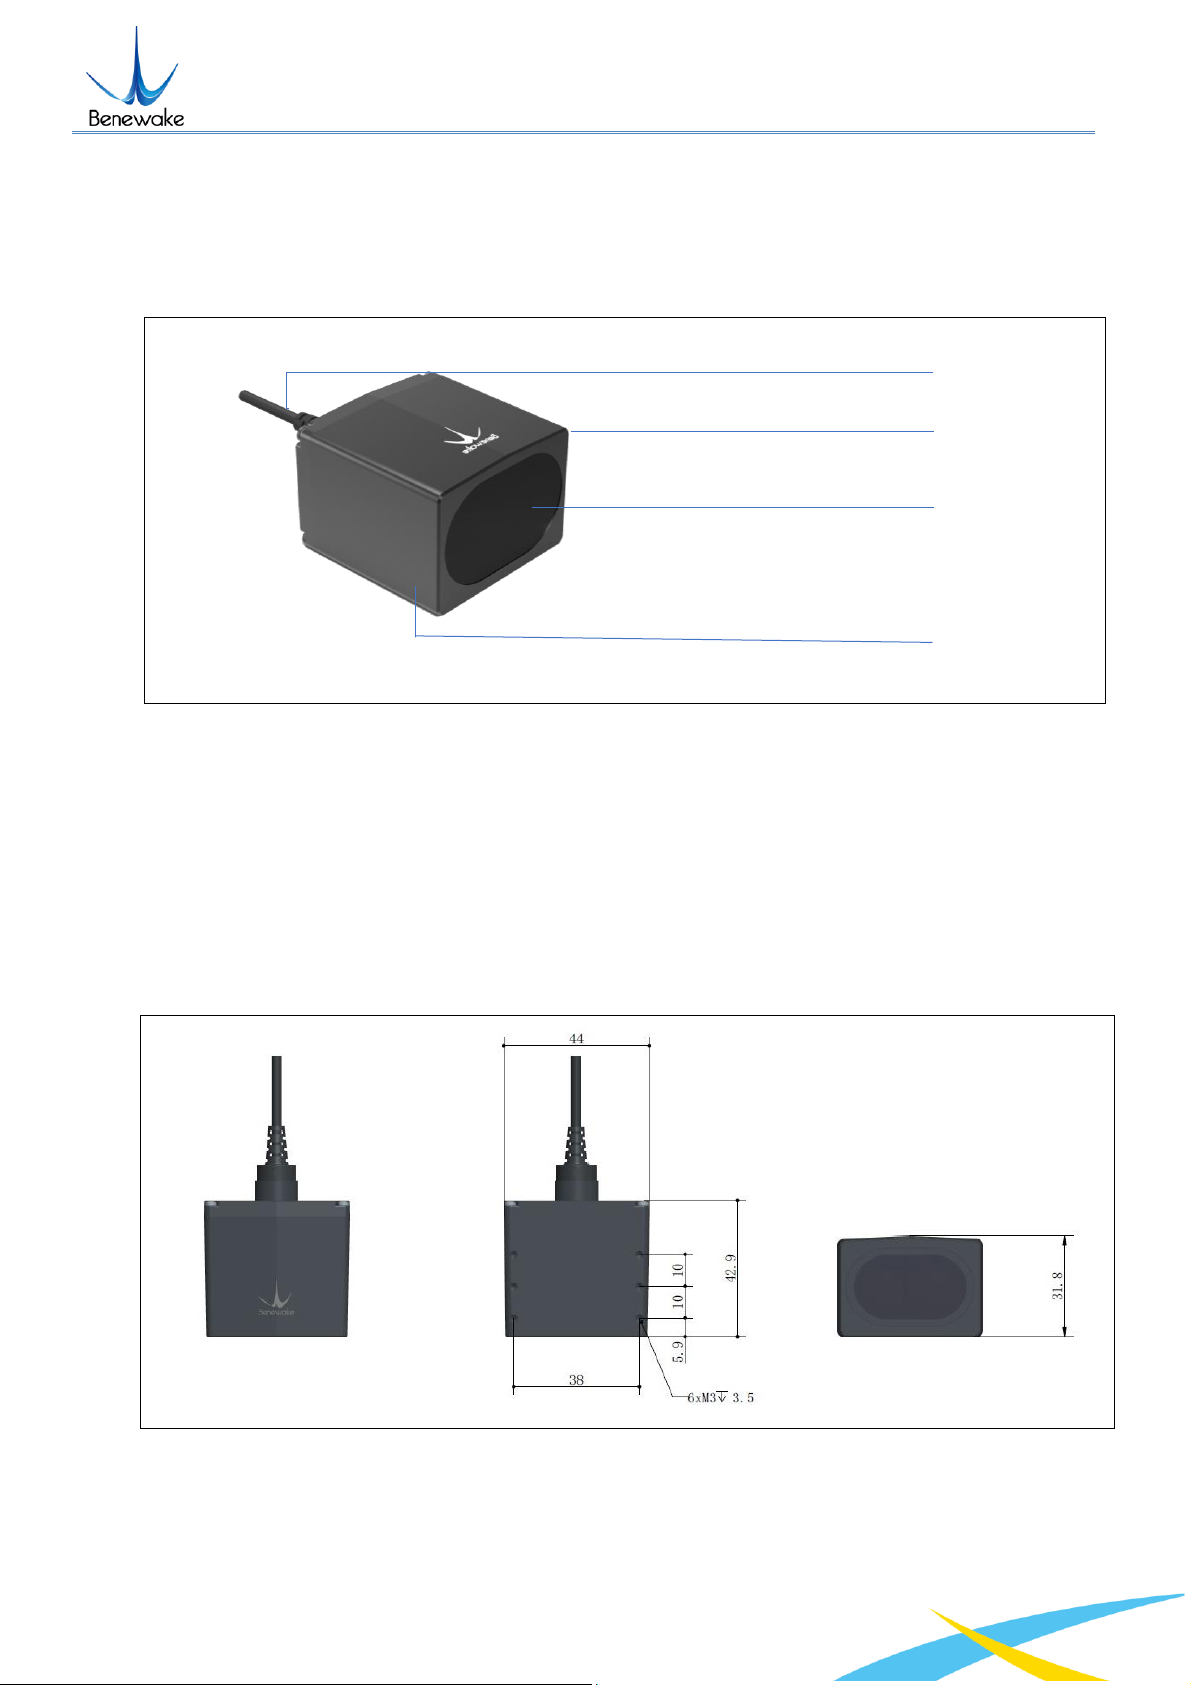
2.1 Appearance Overview
Figure 1 Module view of TF03
① Cable with male connector, Molex SD-51021-007, 7pin
② Laser window (Receiving)
③ Laser window (Emitting)
④ 3mm diameter hole (4mm deep) for mounting (4x)
2.2 Dimensional drawing
Figure 2 Dimensional drawing of TF03 (Left 1: top; Left 2: bottom; Left 3: front; Unit: mm)
② ④ ③
①
Page 8
TF03 UART/CAN User Manual
PRODUCT DESCRIPTION
Page8 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
2.3 Measuring principle
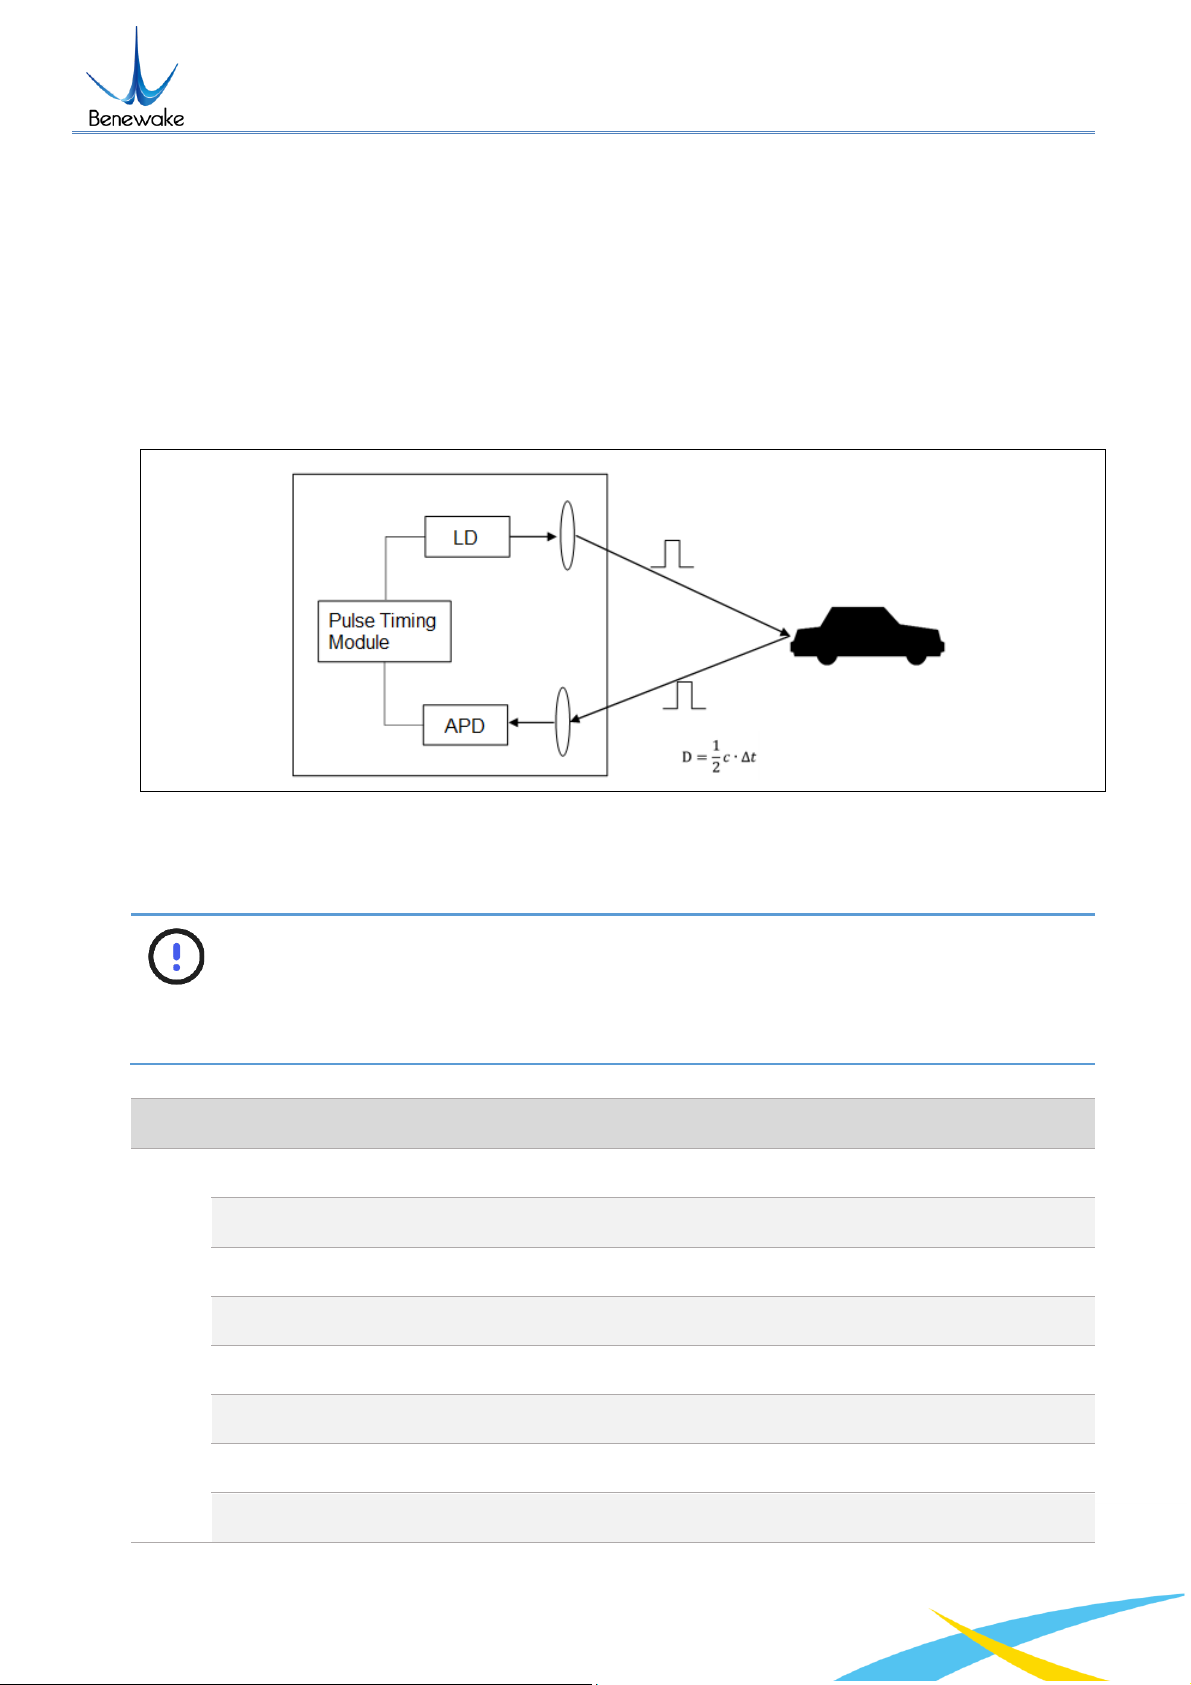
TF03 is a typical Pulse Time of Flight (PToF) sensor. TF03 emits a narrow pulse laser,
which is collimated by the transmitting lens, which enters the receiving system after being
reflected by the measured target and is focused on the APD detector by the receiving lens.
The time between the transmitted signal and the received signal is calculated through the
circuit amplification and filtering, and the distance between TF03 and the measured target
can be calculated through the speed of light.
Figure 3 Pulsed time of flight (PToF)
2.4 Technical specification
NOTICE
TF03 has two versions, TF03-100 and TF03-180. The only difference between
the two versions is the maximum detecting range, which is 100m and 180m
respectively.
Table 2 Technical specifications of TF03
Parameters
Minimum
Typical
Maximum
Performance
Range (@90% reflectivity, 0klux)
0.1m
100m / 180m
Range (@10% reflectivity, 0klux)
0.1m
40m / 70m
Range (@90% reflectivity, 100klux)
0.1m
80m / 130m
Range (@10% reflectivity, 100klux)
0.1m
30m / 50m
Accuracy
±10cm (within 10m), 1% (10m and further)
Distance resolution
1cm
Frame rate
1Hz
100Hz
1000Hz
Repeatability
1σ: <3cm
Page 9
TF03 UART/CAN User Manual
PRODUCT DESCRIPTION
Page9 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
Optical
parameters
Light source
LD
Central wavelength
905nm
Photobiological safety
Class1(EN60825)
FoV 0.5°
Environmen
t
Ambient light immunity
100kLux
Operation temperature
-25℃
60℃
Enclosure rating
IP67
Connections
Supply voltage
5V DC
24V DC
Average current
≤150mA @ 5V, ≤80mA @ 12V, ≤50mA @ 24V
Power consumption
≤1W
Overvoltage protection
300V
Polarity protection
200V
Communication interface level
LVTTL (3.3V)
Communication interface
UART/CAN
Others
Dimension
44mm*43mm*32mm(L*W*H)
Housing
Aluminum alloy
Optical window
Infrared transmitting glass (HWB760)
Storage temperature
-40℃
85℃
Weight
86g
89g
92g
Cable length
70cm
NOTICE
The basic technical specifications, like accuracy and repeatability, are measured
with white background board (90% reflectivity) at 0klux condition.
NOTICE
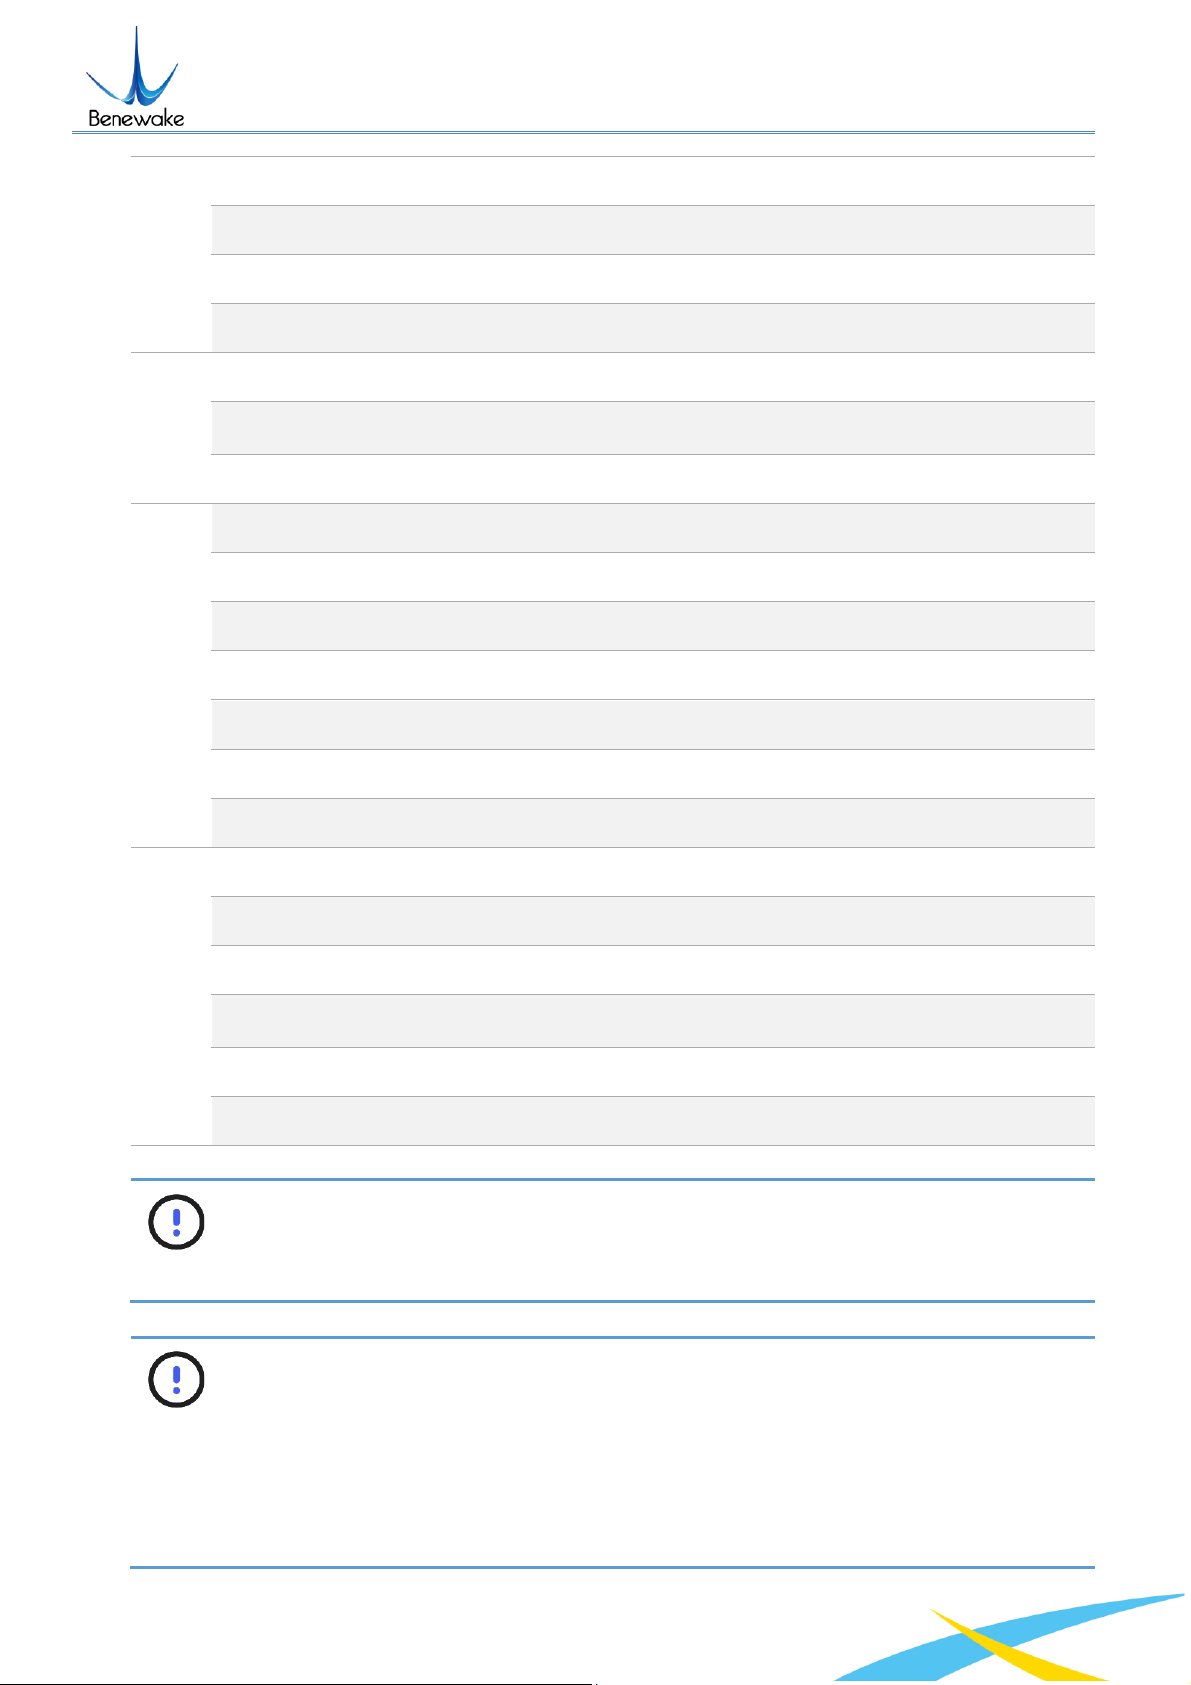
Only the frame rate satisfying the following formula is supported.
If a value does not satisfy this formula is set, TF03 will set its frame rate to
100Hz. The normal frame rate is under 1kHz, but the maximum frame rate can
reach as much as 7kHz. Please contact us if you need higher frame rate.
Page 10
TF03 UART/CAN User Manual
PRODUCT DESCRIPTION
Page10 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
2.5 FoV
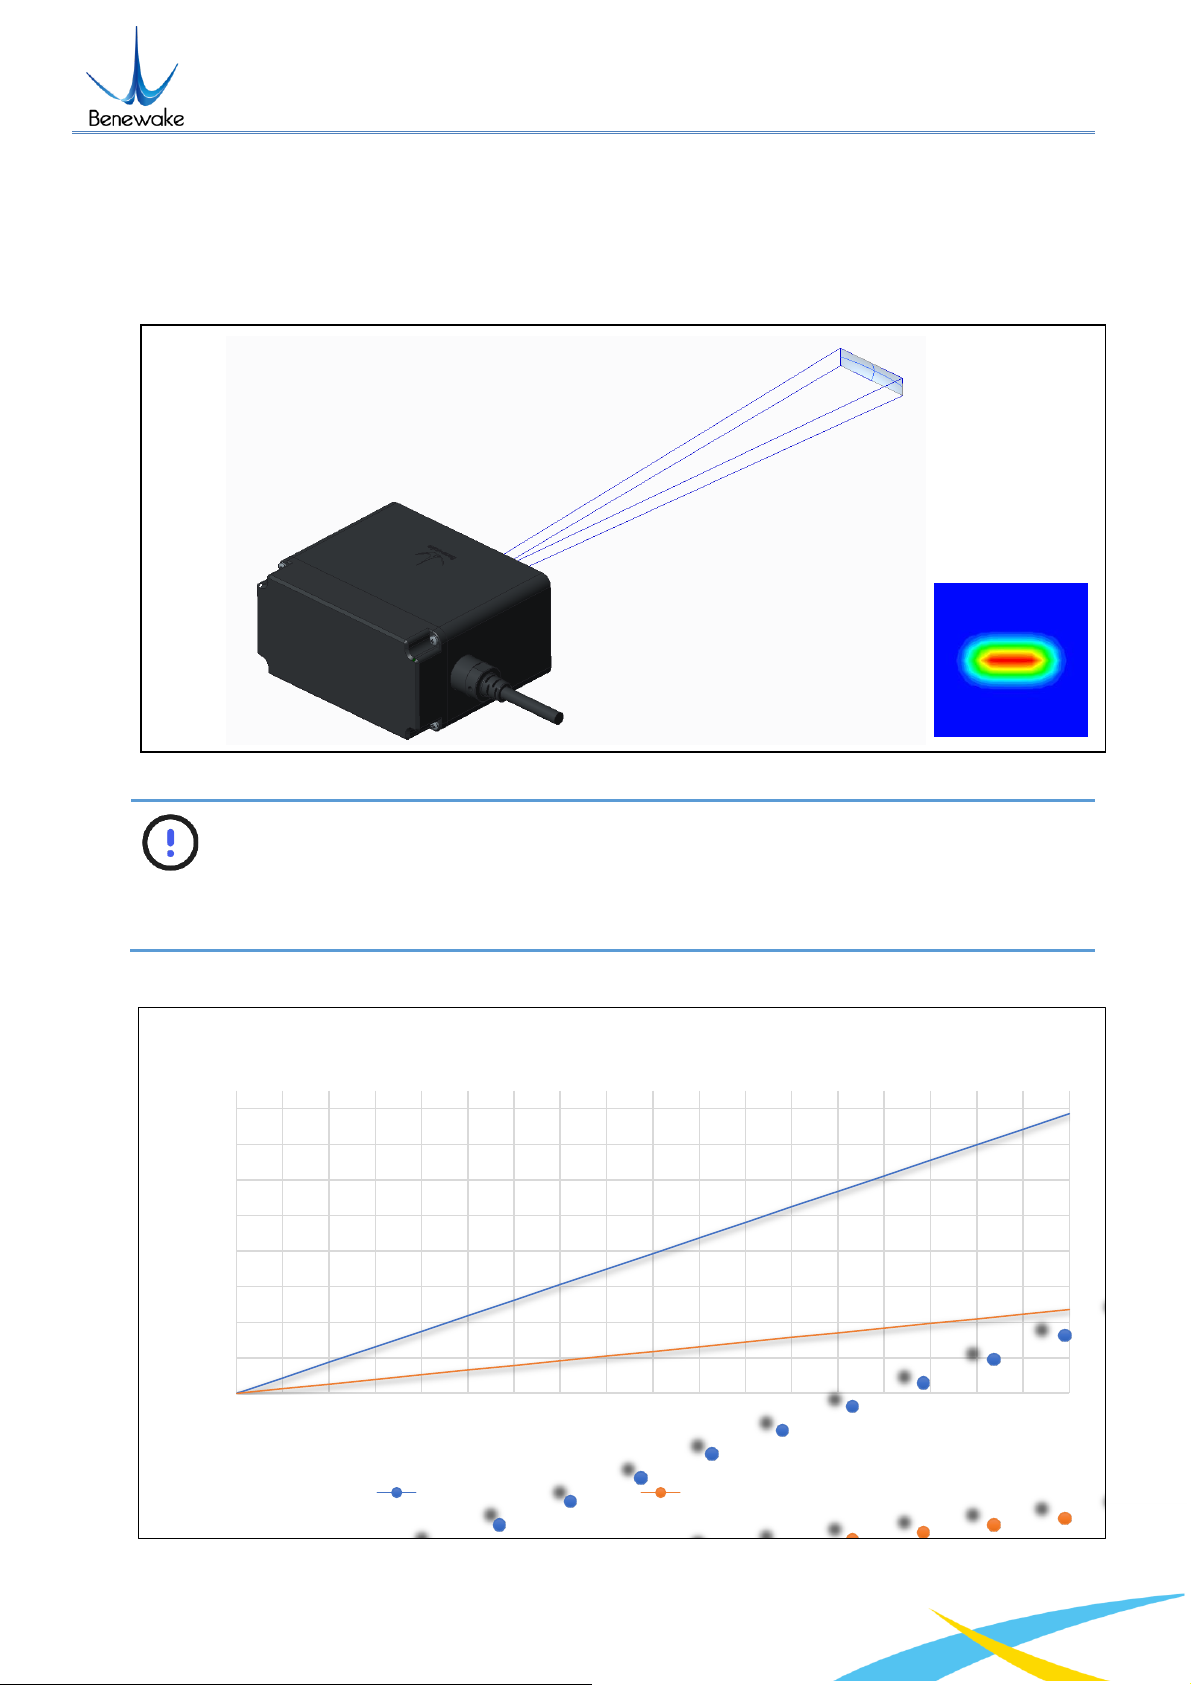
The field-of-view, FoV, is the angle covered by the LiDAR sensor. The horizontal FoV of
TF03 is 0.5° and the vertical FoV of TF03 is 0.15°.
Figure 1 FoV of TF03. Horizontal divergence 0.5°, vertical divergence 0.15°.
NOTICE
0.5° and 0.15° are theoretic values. Because the manufacturing error and the
installing error exist, there is divergence between each TF03’s actual FoV and
its theoretic values.
Figure 4 Spot size of TF03 at different range
0
20
40
60
80
100
120
140
160
0 10 20 30 40 50 60 70 80 90 100 110 120 130 140 150 160 170 180
Spot Size(cm)
Range(m)
Spot Size (W * H) of TF03
Width of Light Spot(cm)
Divergence 0.5 degree
Height of Light Spot(cm)
Divergence 0.15 degree
Page 11
TF03 UART/CAN User Manual
ELECTRICAL INSTALLATION
Page11 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
3 ELECTRICAL INSTALLATION
3.1 Pin and wire color assignment
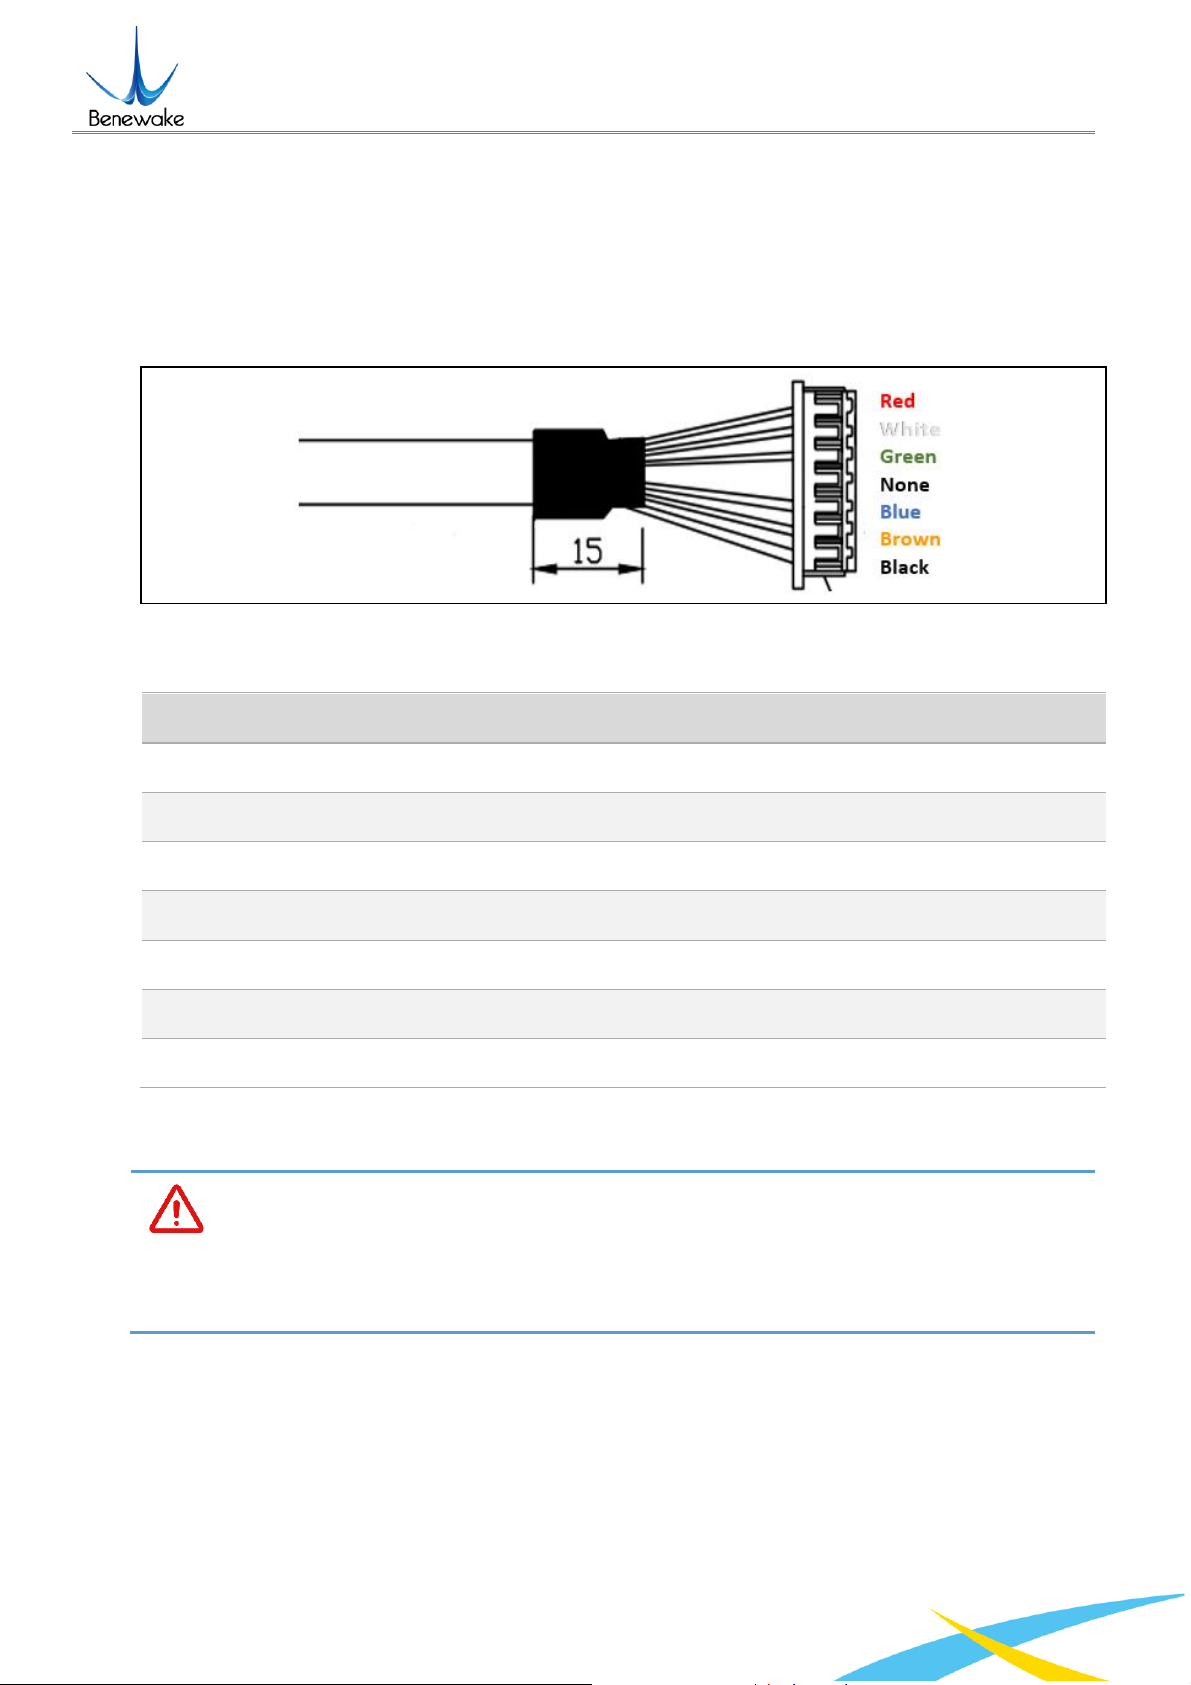
TF03’s cable has six 26 AWG wires. The connector is Molex SD-51021-007 1.25 W/B-7Pin.
Figure 5 Male connector, Molex SD-51021-007 1.25 W/B-7Pin
Table 3 Pin assignment on 7-pin male connector
Pin
Color
Signal
Function
1
Red
DC 5~24V
Supply voltage
2
White
CAN_L
CAN-BUS Low
3
Green
CAN_H
CAN-BUS High
4
N/A
N/A
N/A
5
Blue
UART RxD
UART receive
6
Brown
UART TxD
UART Transmit
7
Black
GND
Ground
3.2 Wire cross-sections
CAUTION
If you use flexible connecting cables with stranded wire, then you must not use
ferrules when connecting the wires to the terminals on TF03.
Wire all connections with copper cables!
➢ Use the following wire cross-sections:
⚫ supply voltage at least 0.13 mm² (approx. 26 AWG), if local power supply in the
immediate vicinity.
⚫ supply voltage at least 0.21 mm² (approx. 24 AWG) at maximum length of 2m (6.562 ft),
if the connection is made to an existing 24 V DC supply.
⚫ switching outputs minimum 0.13 mm² (approx. 26 AWG), maximum cable length 2m
Page 12
TF03 UART/CAN User Manual
ELECTRICAL INSTALLATION
Page12 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
(6.562 ft) with 0.21 mm² (approx. 24AWG).
⚫ data interface minimum 0.13mm² (approx. 26AWG).
➢ Lay all cables such that there is no risk of tripping and all cables are protected against
damage.
On the usage of a typical power supply with a nominal voltage of 24V DC ±5%, the
following maximum cable lengths are allowed for the supply of the operating voltage:
Table 4 Maximum cable lengths for the supply voltage
Wire cross-section
Cable length
0.13 mm2 (approx. 26AWG)
4 m (13.1 ft)
0.32 mm2 (approx. 22AWG)
10 m (32.81 ft)
3.3 General conditions for data interface
The table below shows the recommended maximum length of cable as a function of the
data transmission rate selected.
Table 5 Maximum cable lengths for the data interfaces
Interface type
Transmission rate
Maximum cable length
CAN bus
1MBit/s
10 m (32.81ft)
UART
115 200 Bd
1.5 m (4.92ft)
NOTICE
With appropriate cable termination, termination in accordance with related
specification.
⚫ Use screened cable(twisted-pair) with at least 26 AWG.
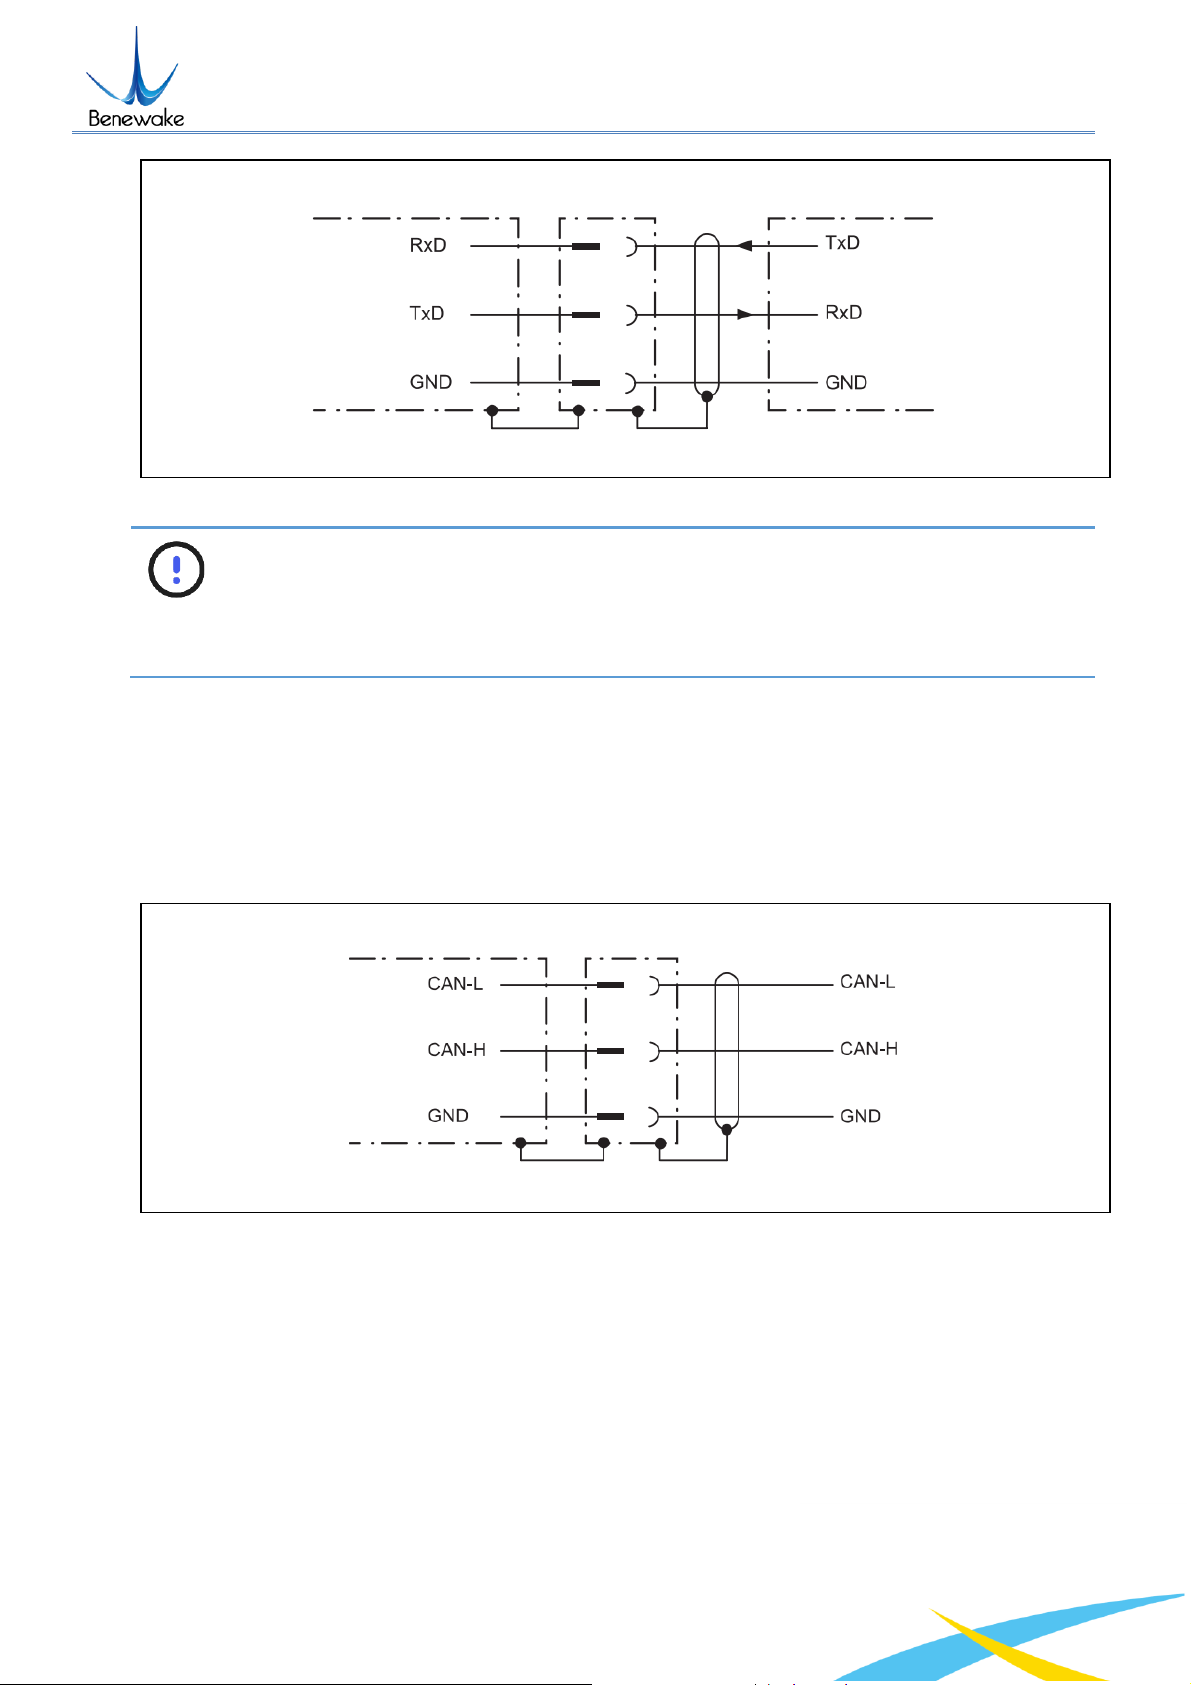
3.4 Wiring the UART Interface
A screened cable is required for the wiring of the UART interface.
Pay attention to max. cable length as per section 3.3 “General conditions for the data
interface”.
Page 13
TF03 UART/CAN User Manual
ELECTRICAL INSTALLATION
Page13 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
Figure 6 Wiring of the UART interface
NOTICE
To connect two devices for UART serial communication, the transmitter’s TX
should connect to the receiver’s RX and the receiver’s TX should connect to the
transmitter’s RX.
3.5 Wiring the CAN Interface
To wire the CAN interface a screened “twisted-pair” cable is required.
Pay attention to max. cable length as per section 3.3 “General conditions for the data
interface”.
Figure 7 Wiring of the CAN interface
3.6 CAN Bus
Unlike a traditional network such as USB or Ethernet, CAN does not send large blocks of
data point-to-point from one node to another under the supervision of a central bus master.
Once CAN basics such as message format, message identifiers, and bit-wise arbitration -a major benefit of the CAN signaling scheme are explained, a CAN bus implementation is
examined, typical waveforms presented, and transceiver features examined.
Page 14
TF03 UART/CAN User Manual
ELECTRICAL INSTALLATION
Page14 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
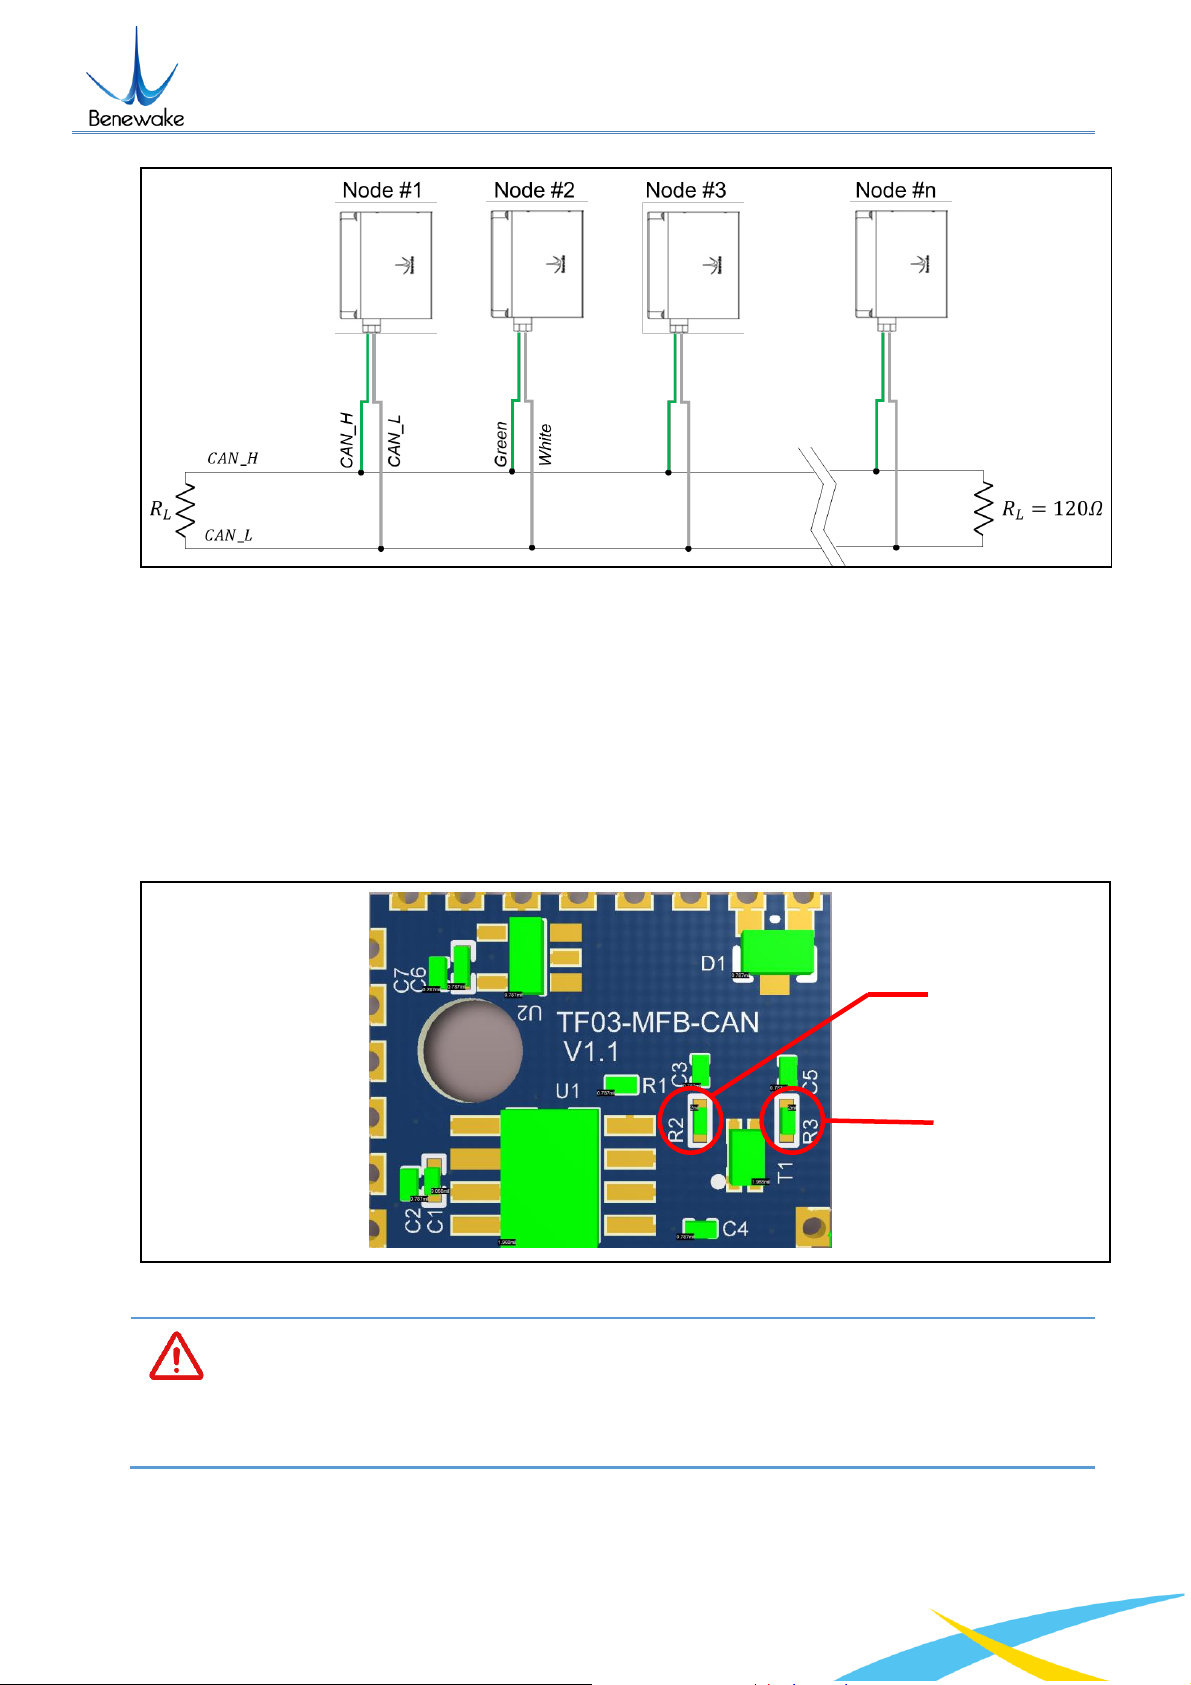
Figure 8 CAN networking of TF03
The High-Speed ISO 11898 Standard specifications are given for a maximum signaling
rate of 1 Mbps with a bus length of 40 m with a maximum of 30 nodes. It also recommends
a maximum unterminated stub length of 0.3 m. The cable is specified to be a shielded or
unshielded twisted-pair with a 120-Ω characteristic impedance (Zo).
For CAN bus connection, there are two resistances need to be removed from TF03. See
Figure 9 Resistances needed to be removed from PCBA for CAN Bus for the location of
Resistance #2 and #3.
Figure 9 Resistances needed to be removed from PCBA for CAN Bus
WARNING
Removing resistance #2 and #3 needs to disassemble TF03. To avoid
irreversible damage to TF03, please contact our technical support engineers for
detailed instructions.
R2
R3
Page 15
TF03 UART/CAN User Manual
COMMUNICATION PROTOCOLS
Page15 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
4 COMMUNICATION PROTOCOLS
The standard version of TF03 supports two communication interfaces, UART and CAN.
The default interface is UART. These two interfaces cannot work simultaneously. The
communication interface can be switched by certain command.
4.1 Communication protocol of UART
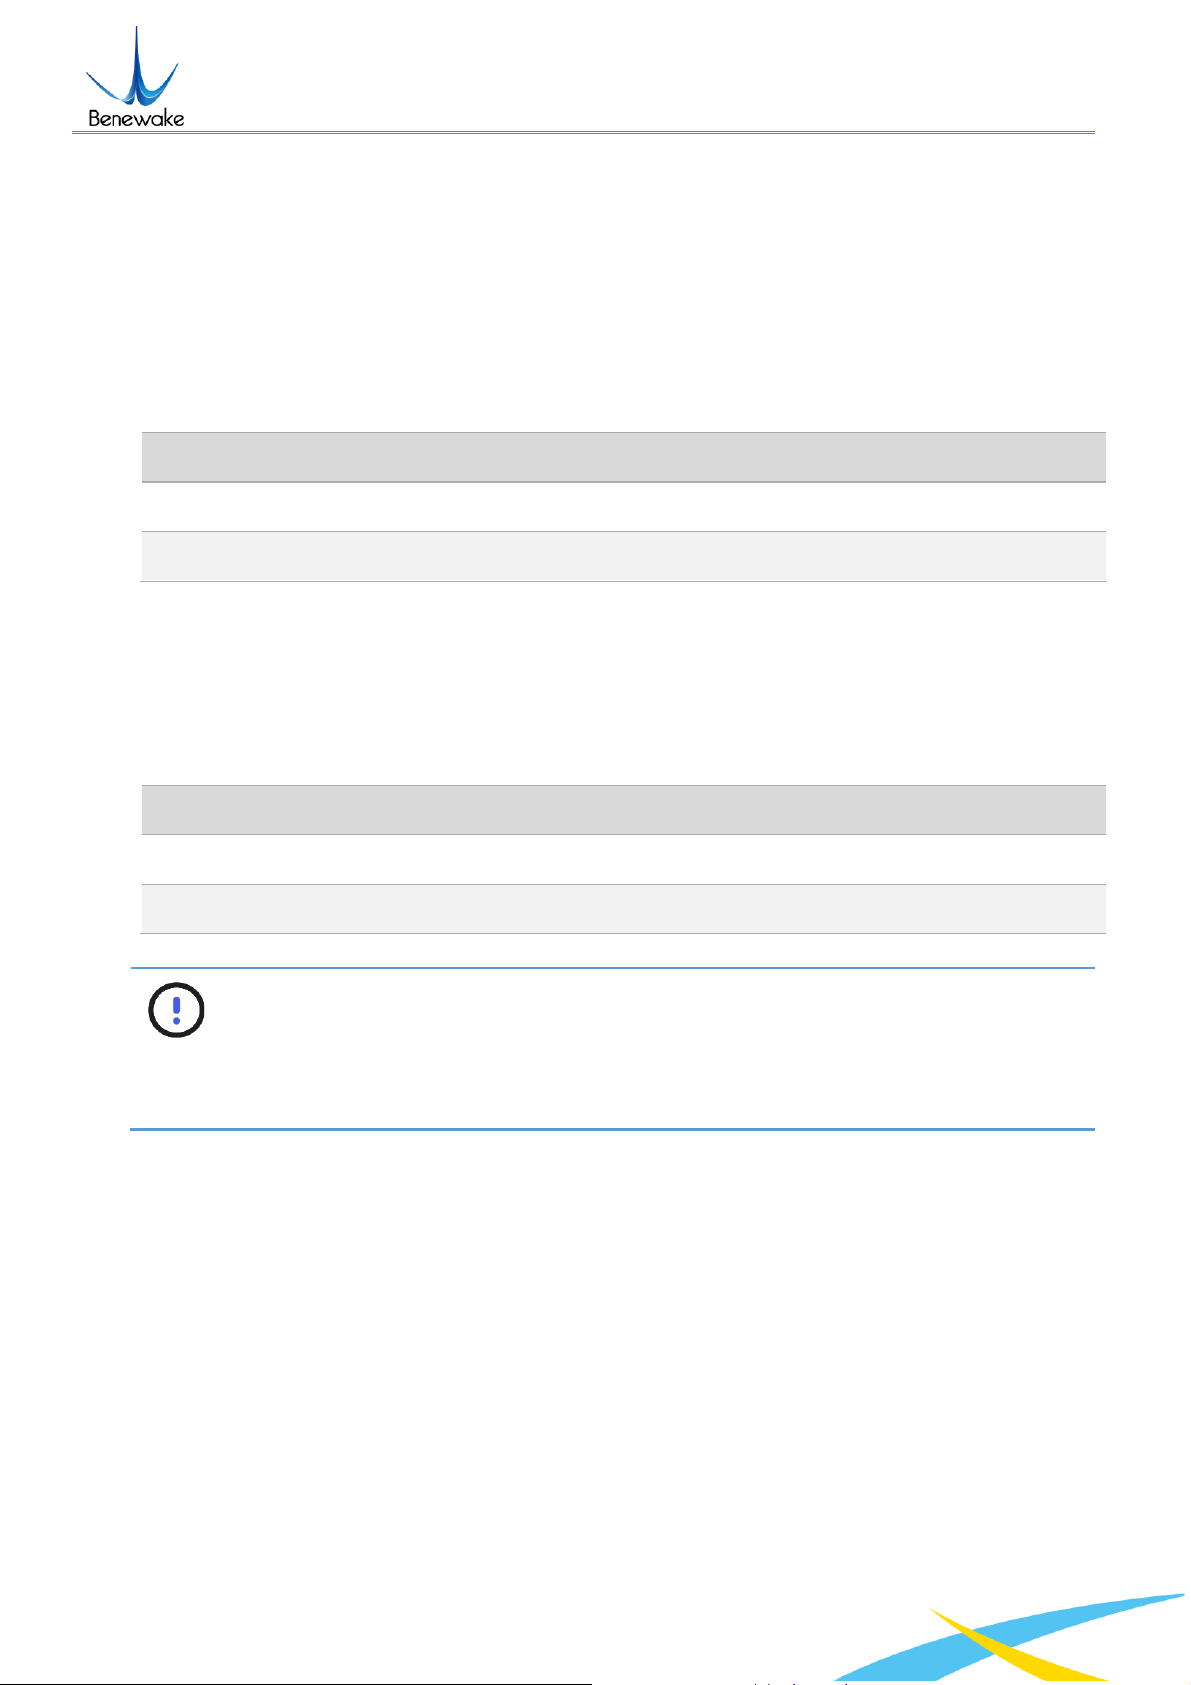
Table 6 Characteristics of UART
Character
Value
Configurability
Baud rate
115200
Configurable
Data bit
8
Non-configurable
Stop bit
1
Non-configurable
Parity
None
Non-configurable
4.2 User protocol of UART
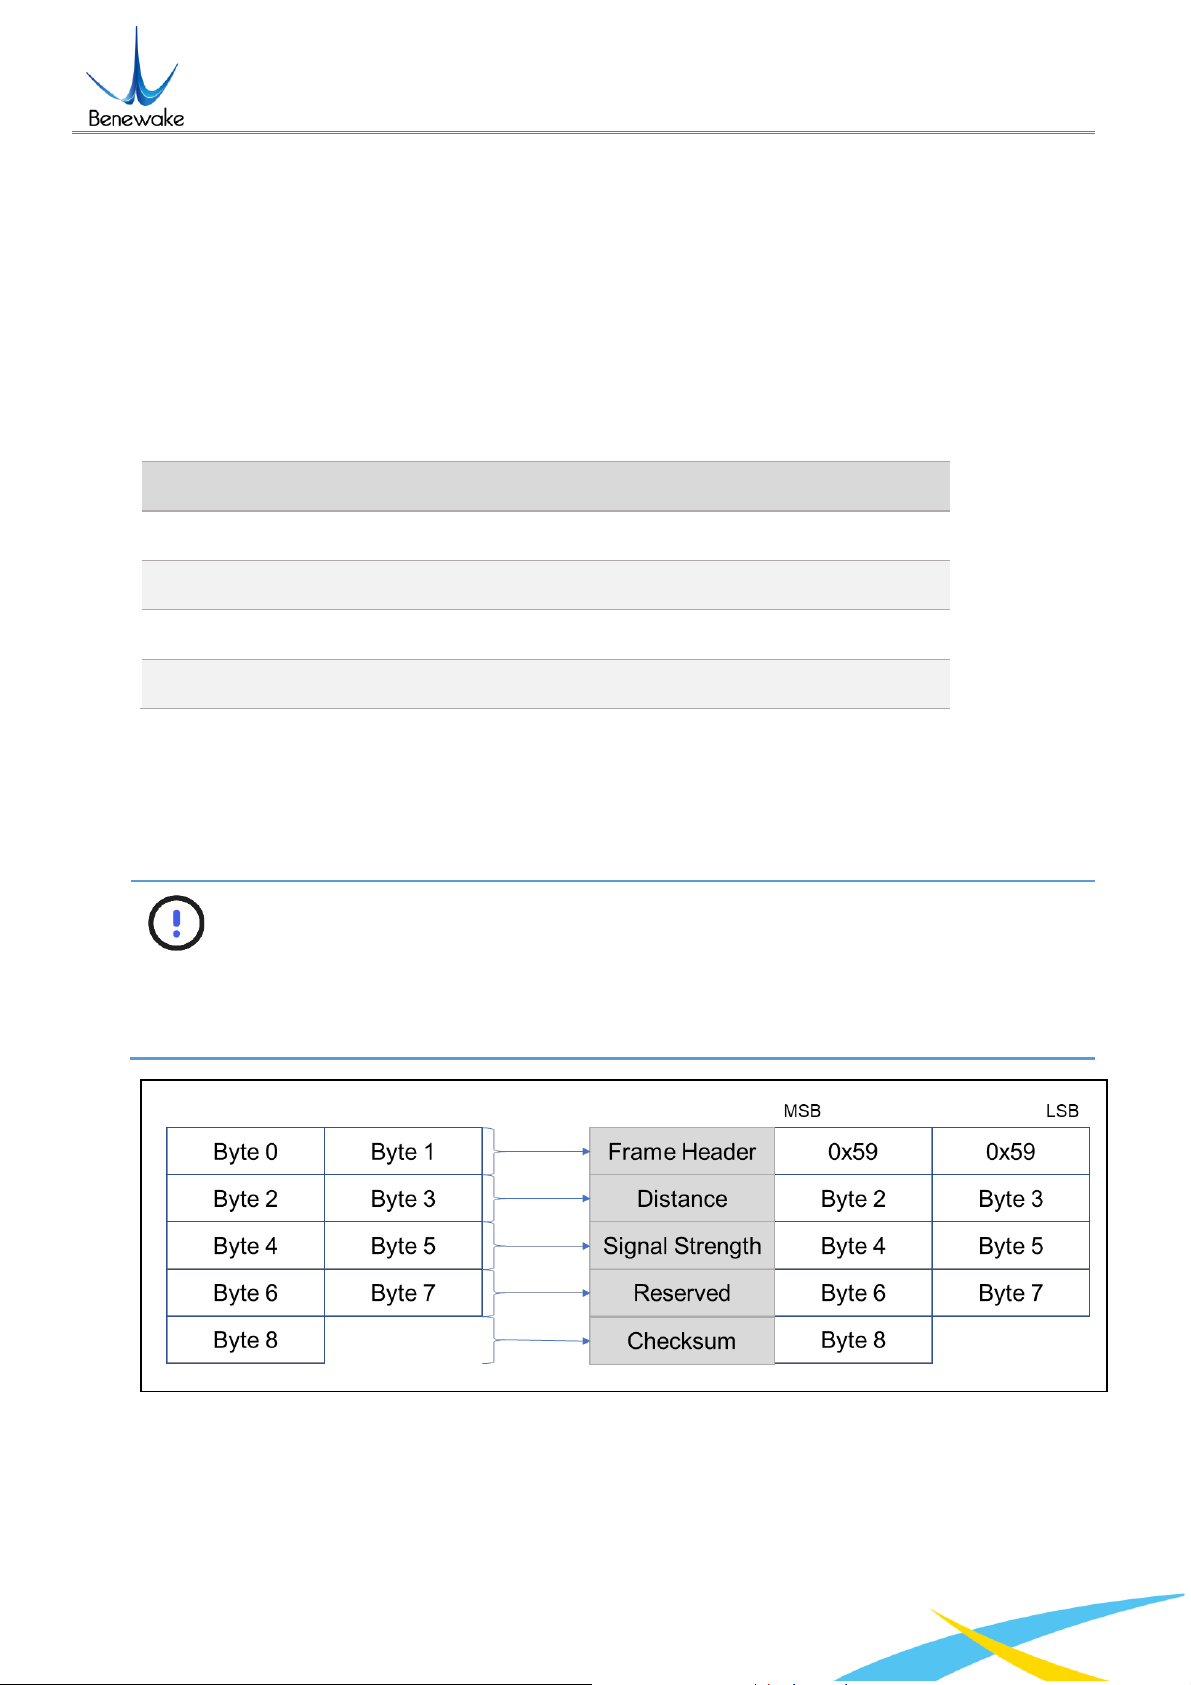
A standard data frame consists of 9 bytes of hexadecimal numbers, which contains
distance and signal strength.
NOTE
Strength value is between 0 and 3500. Threshold of strength is 40, when
strength is lower than 40, distance will output maximum value. When strength is
between 40 and 1200, distance is more reliable. When there is a high reflectivity
object, strength will be over 1500.
Figure 10 Data communication: User protocol frame format of UART
Each data frame consists of 9 bytes hexadecimal data which contains the distance and
signal strength.
Page 16
TF03 UART/CAN User Manual
CUSTOM CONFIGURATION
Page16 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
NOTE
Strength value is between 0 and 3500. Threshold of strength is 40, when
strength is lower than 40, distance will output maximum value. When strength is
between 40 and 1200, distance is more reliable. When there is a high reflectivity
object, strength will be over 1500.
4.3 Communication protocol of CAN
Table 7 Characteristics of CAN
Character
Value
Configurability
Baud rate
1M Bit/s
Configurable
Receiving ID
0x3003
Configurable
Transmitting ID
0x03
Configurable
Message frames
Standard Frame
Extended Frame
Configurable
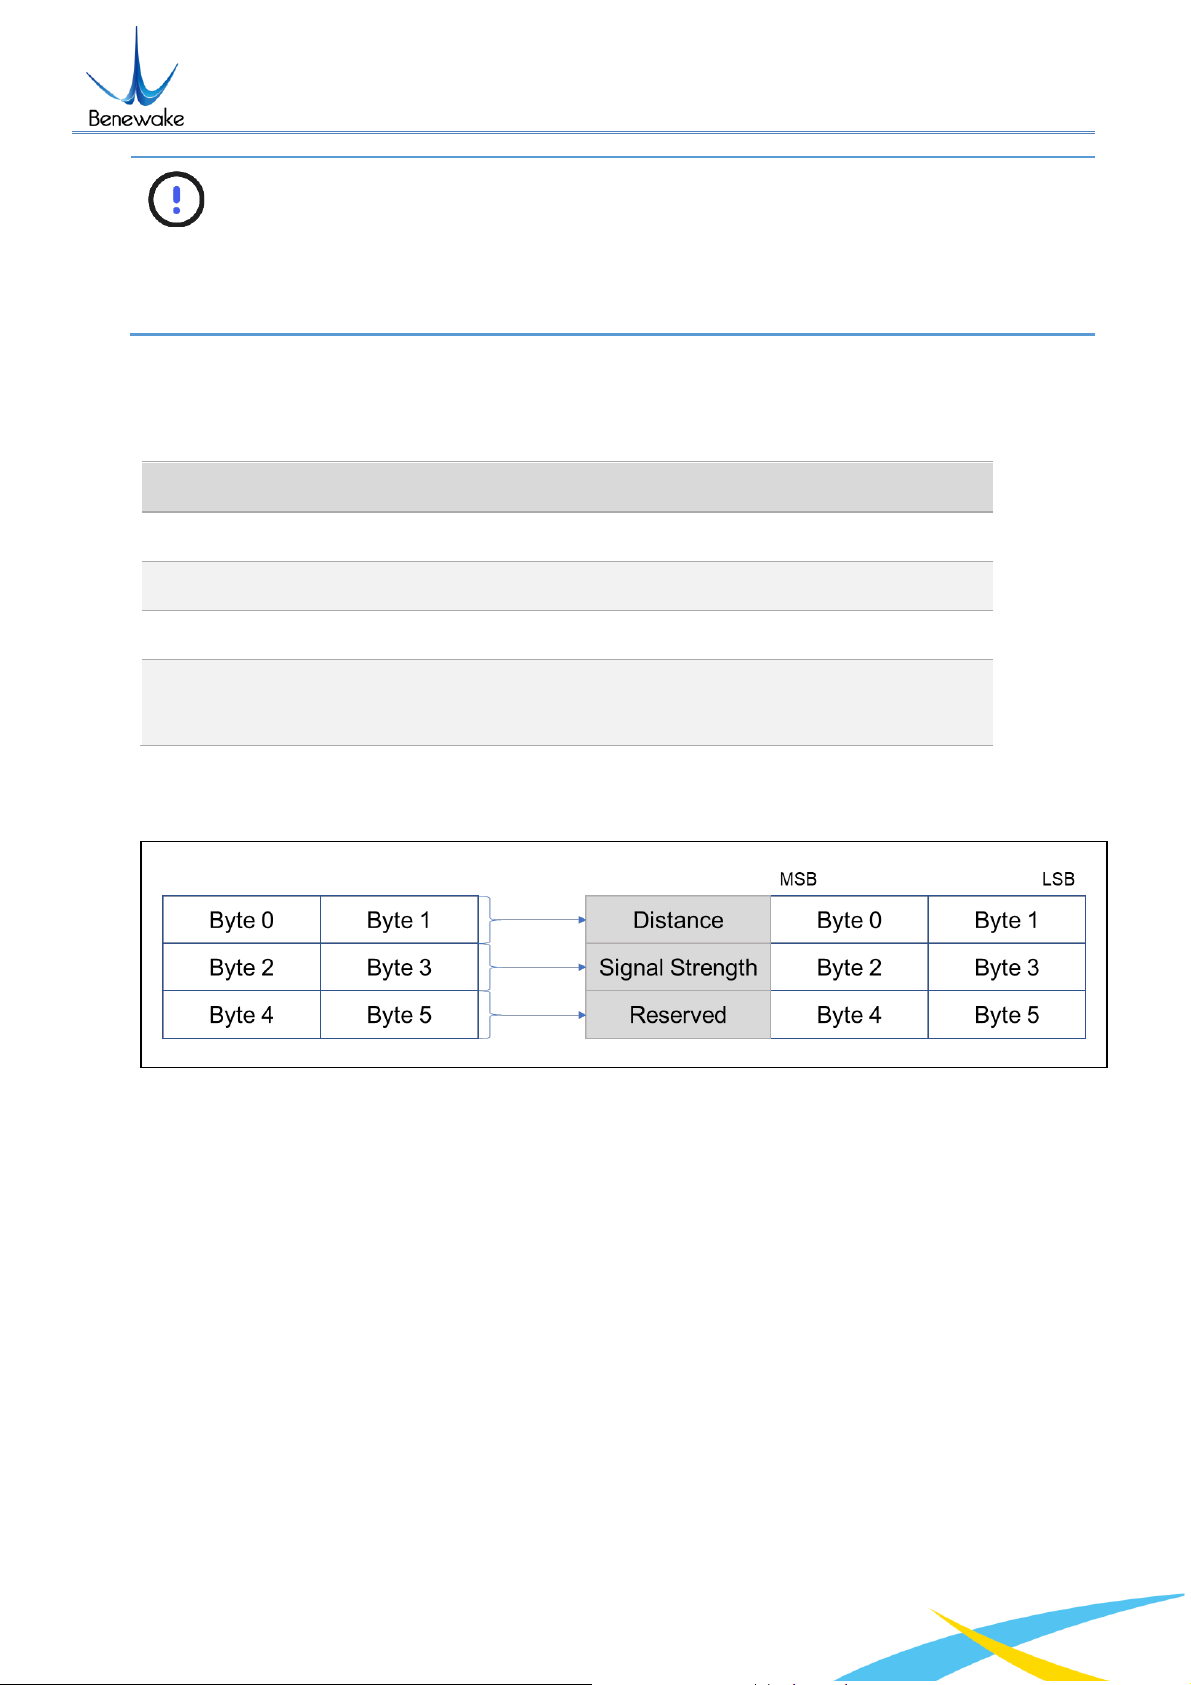
4.4 User protocol of CAN
Figure 11 Data communication: User protocol frame format of CAN
5 CUSTOM CONFIGURATION
5.1 Command protocol
To meet the need of different customers, TF03 released several configuration parameters.
These parameters, such as data format, frame rate, could be modified by certain command.
All the parameters will be stored in flash after configured successfully and customers don’t
need to configure again when restart.
Page 17
TF03 UART/CAN User Manual
CUSTOM CONFIGURATION
Page17 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
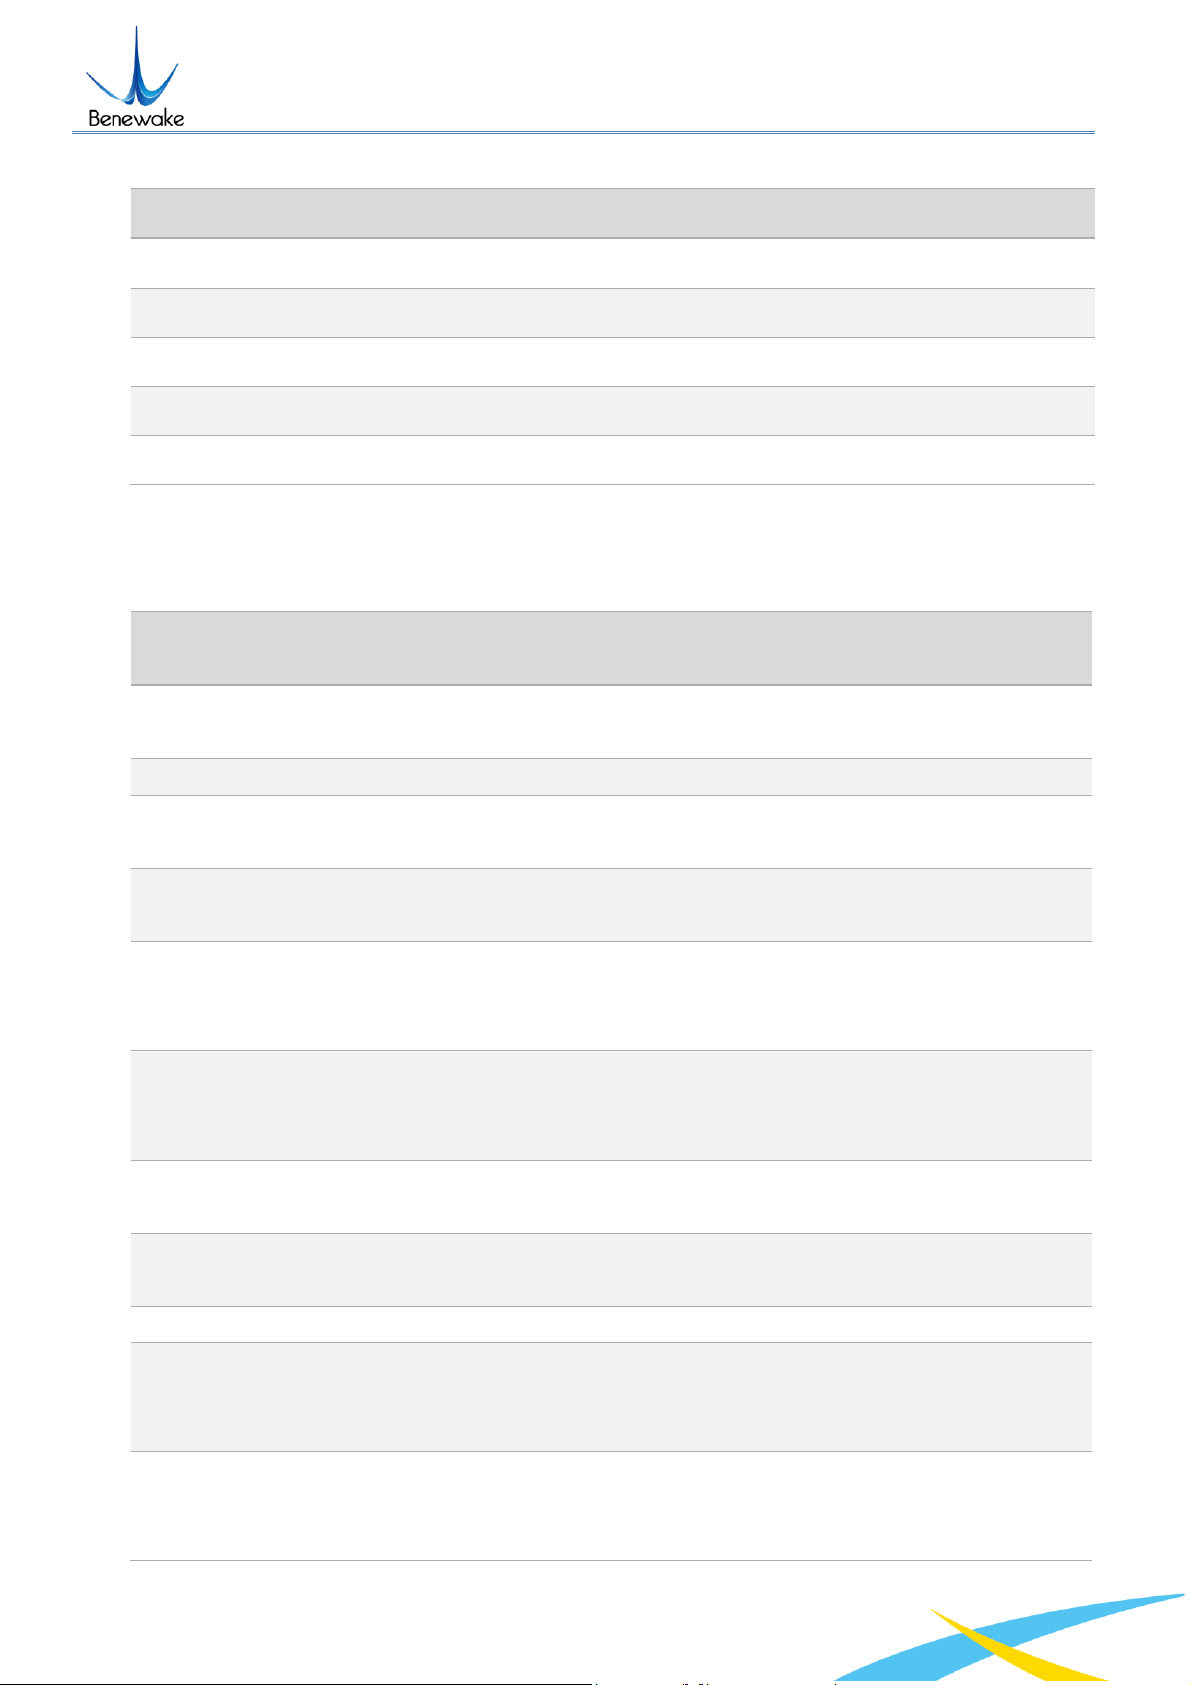
Table 8 Description of TF03 command protocol
Byte
Definition
Description
Byte 0
Header
Fixed to 0x5A
Byte 1
Len
The length of the command frame (unit: Byte)
Byte 2
ID
Identifies the function of each command
Byte 3~Byte N-2
Payload
Different meanings and lengths in different ID command frames
Byte N-1
Check sum
the lower 8 bits of the sum of the first N-2 bytes
5.2 Common commands
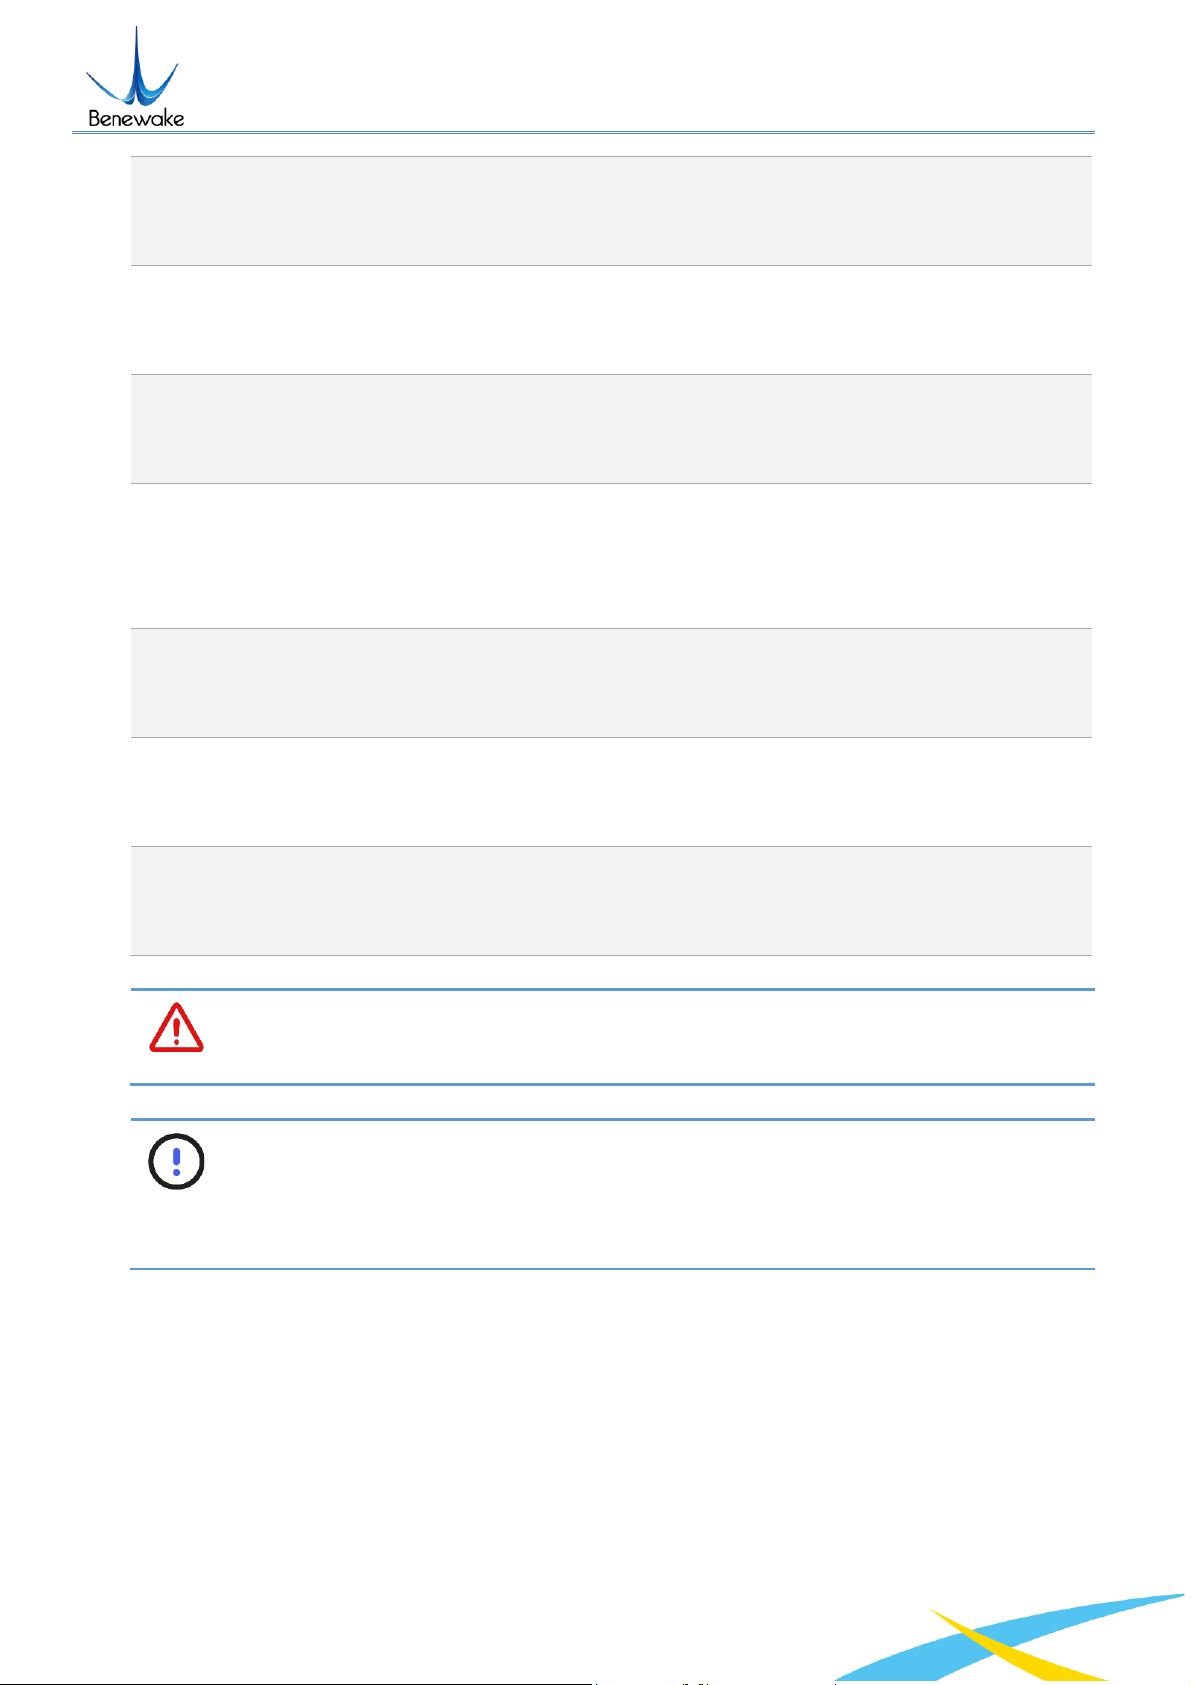
Table 9 List of TF03’s common commands
Description
Command
Response
Remark
Default
setting
Obtain firmware
version
5A 04 01 5F
5A 07 01 VA VB
VC SU
The version number
VC.B.A
/
System reset
5A 04 02 60
5A 05 02 00 61
/
/
Modify frame
rate
5A 06 03 LL HH SU
Same as
command
LL: lower 8 bits
HH: higher 8 bits
100Hz
Output control
On: 5A 05 07 01 67
Off: 5A 05 07 00 66
Same as
command
/
Enabled
Enable
command
triggering mode
5A 05 07 00 66
Same as
command
/
Disabled
Trigger
measurement
5A 04 04 62
Data frame
Only works in
command triggering
mode
/
Change baud
rate
5A 08 06 H1 H2 H3 H4
SU
Same as
command
See 5.3 Command
editing
115200
Restore default
settings
5A 04 10 6E
5A 05 10 00 6F
/
/
Save settings
5A 04 11 6F
5A 05 11 00 70
/
/
Over range
threshold
setting
5A 06 4F LL HH SU
5A 05 4F 00 AE
Unit: cm
LL: lower 8 bits
HH: higher 8 bits
35000
Switch
communication
interface
UART: 5A 05 45 01 A5
CAN: 5A 05 45 02 A6
5A 05 45 00 A4
/
UART
Page 18
TF03 UART/CAN User Manual
CUSTOM CONFIGURATION
Page18 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
Modify CAN
arbitration ID
5A 08 50 H1 H2 H3 H4
SU
5A 05 50 00 AF
ID = (H4<<24)
+(H3<<16) +(H2<< 8)
+H1
0x03
Modify CAN
5A 08 51 H1 H2 H3 H4
SU
5A 05 51 00 B0
ID=(H4<<24)
+(H3<<16) +(H2<< 8)
+H1
0x3003
Modify baud
rate of CAN
5A 08 52 H1 H2 H3 H4
SU
5A 05 52 00 B1
Baud rate=(H4<<24)
+(H3<<16) +(H2<<8)
+H1
1Mbits/s
Set frame type
of CAN
Standard frame: 5A 05
5D 00 BC
Extension frame: 5A
05 5D 01 BD
5A 05 5D 00 BC
/
Standard
frame
Enable
UAVCAN
5A 05 77 MD SU
5A 05 77 00 D6
MD:filter switch
0x00:filter off
0x01:filter on
/
Offset setting
5A 06 69 LL HH SU
5A 05 69 00 C8
Unit: cm
LL: lower 8 bits
HH: higher 8 bits
0
Low-power
consumption
mode
On: 5A 05 83 01 E3
Off: 5A 05 83 00 E2
Same as
command
/
Off
WARNING
Do not send the command that is not in the list above.
NOTE
Baud rate of UART can be set to 9600, 14400, 19200, 38400, 56000, 57600,
115200, 128000, 230400, 256000, 460800, 512000, 750000, and 921600. If
other value were set, TF03 will set it to 115200.
5.3 Command editing
This section describes the Command Channel of TF03 which is used to read and set
TF03’s working parameters. The command channel is available via all the interfaces.
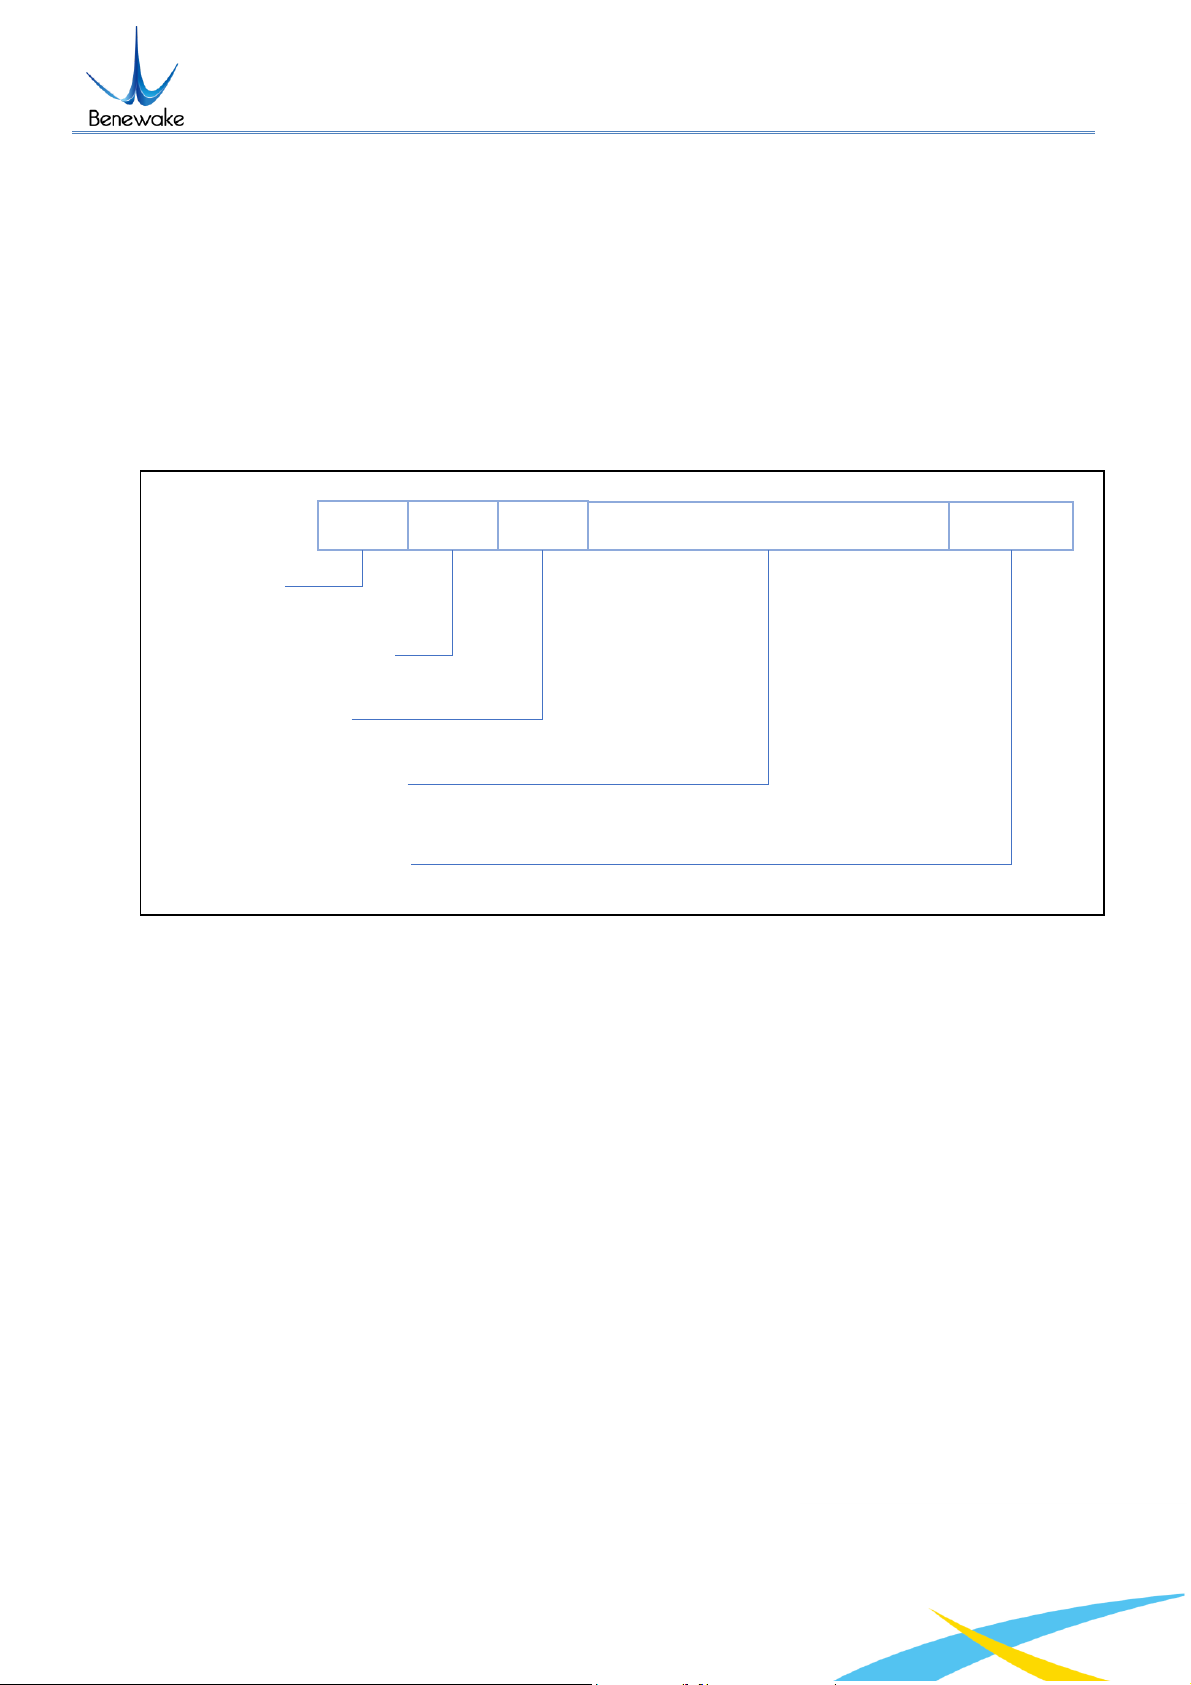
A standard TF03 command consists of frame header, command length, command ID,
parameters and checksum. Follow these steps to generate a command:
⚫ Choose the right command ID and confirm its length
Page 19
TF03 UART/CAN User Manual
OPTIONAL ACCESSORIES
Page19 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
⚫ Convert parameter from the decimal value to hexadecimal value
⚫ Fill the hexadecimal parameter into the command
⚫ Calculate the checksum and fill its low 8-bits into the command
For example, changing the baud rate to 460800. Firstly, choose the ID of changing frame
rate, which is 0x06. Secondly, change 460800 (decimal number) to hexadecimal number,
which is 0x00 07 08 00. Thirdly, fill the parameter into the command, like 5A 08 06 00 08
07 00 SUM. Finally calculate the sum of the first 7bytes and take its low 8bits, we will have
the complete command, 5A 08 06 00 08 07 00 77.
Figure 12 Command syntax of TF03
6 OPTIONAL ACCESSORIES
6.1 Self-cleaning module
In some outdoor scenes, dust adhering to the TF03’s window will affect the performance of
the TF03. We’ve designed the following self-cleaning module that can automatically clean
the TF03’s window regularly. The module drives the rocker arm and wiper with the steering
gear to clean the TF03 window regularly.
Header
Length
ID
Hexadecimal parameters
Checksum
Fixed: 0x5A
Length of the command
(Number of bytes)
ID of the command
Hexadecimal parameters
Little-endian mode
Lower 8 bits of the sum of
previous bytes
Page 20
TF03 UART/CAN User Manual
OPTIONAL ACCESSORIES
Page20 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
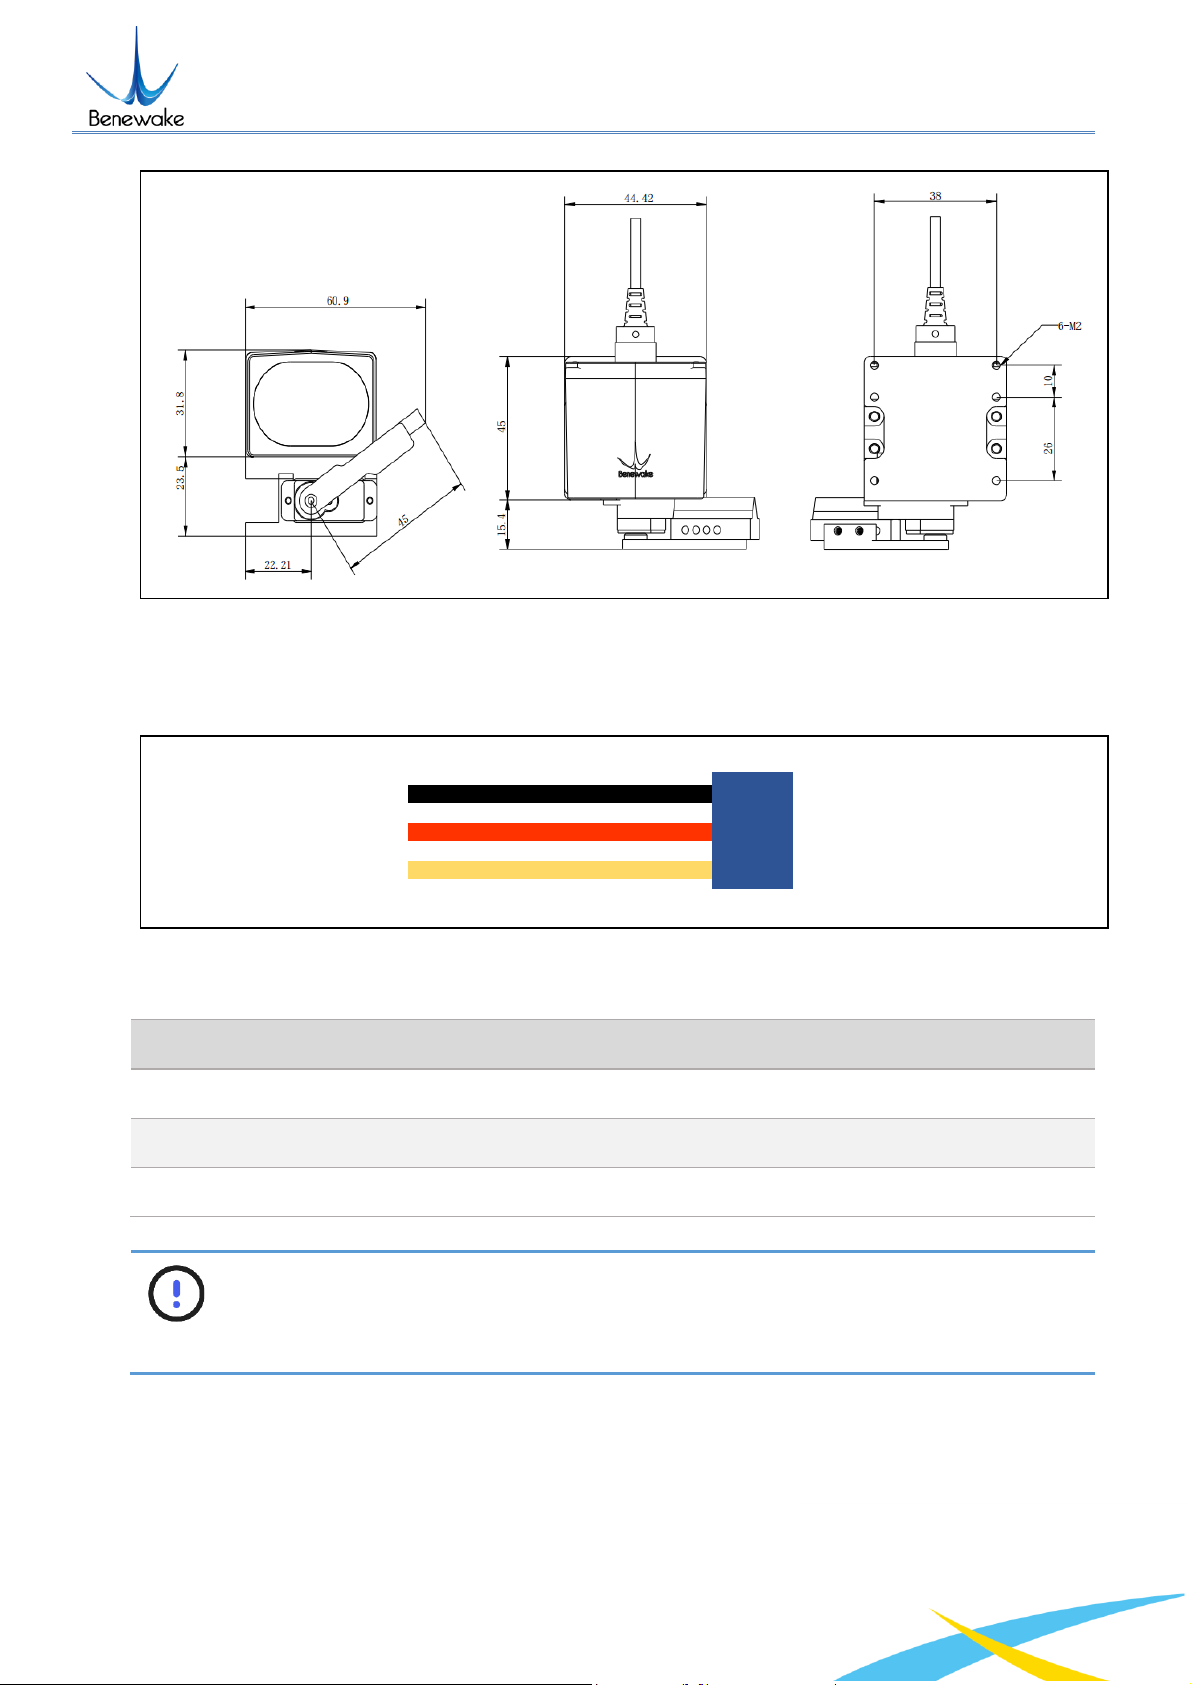
Figure 13 Dimension drawing of self-cleaning module
The self-cleaning module is fixed with TF03 through the metal base, its power supply and
communication are completely independent from TF03.
Figure 14 Sketch map of steering gear
Table 10 Pin assignment of steering gear
Pin
Color
Signal
Function
1
Black/Brown
GND
Ground
2
Red
DC +5V
Supply voltage
3
Yellow
PWM
Signal channel
NOTE
The working pattern of steering gear is configurable, please contact us for
detailed information.
①
②
③
Page 21
TF03 UART/CAN User Manual
OPTIONAL ACCESSORIES
Page21 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
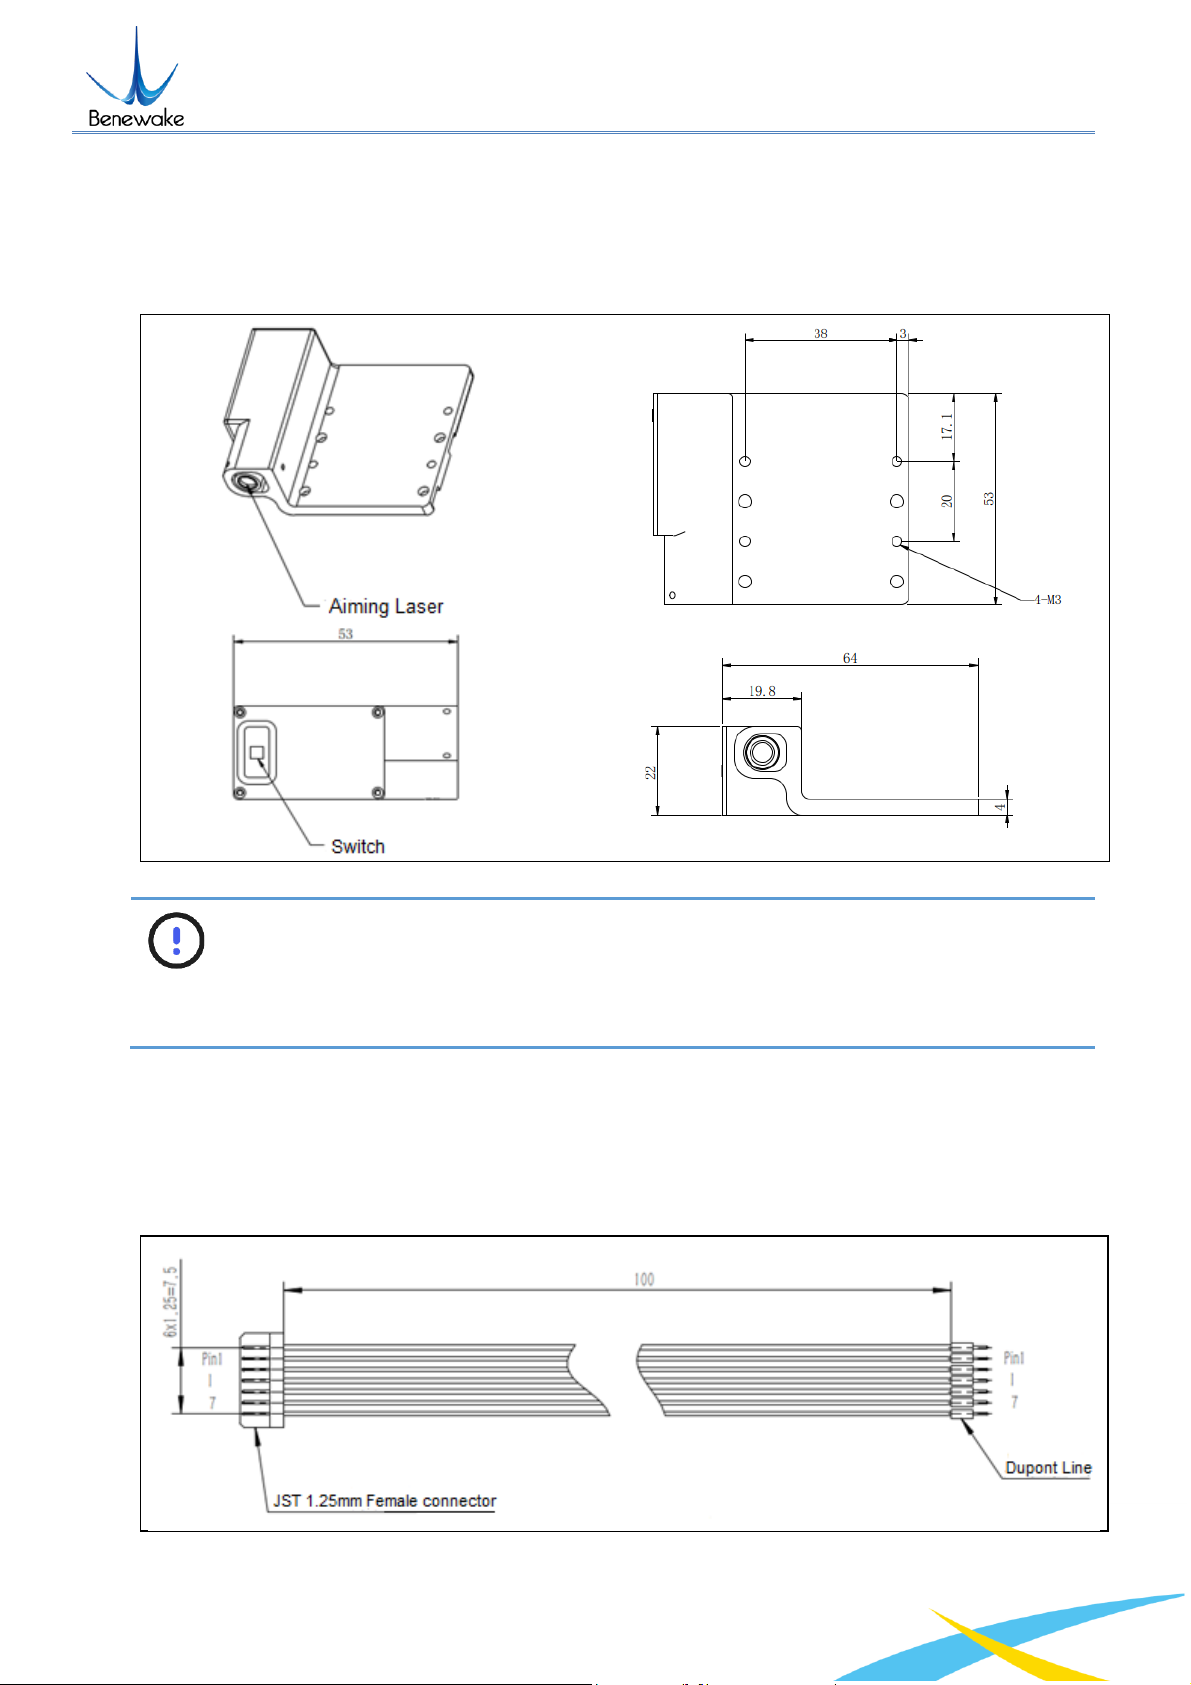
6.2 Aiming beam module
The wavelength of TF03’s detecting light is 905nm, which is invisible light. We’ve designed
an aiming beam module to assist the installation.
Figure 15 Sketch map of Aiming beam module
NOTE
The aiming beam powered by button battery is a low-power laser. Its indoor
effective range is approximate 150 meters, and its outdoor effective range is
about 30 meters.
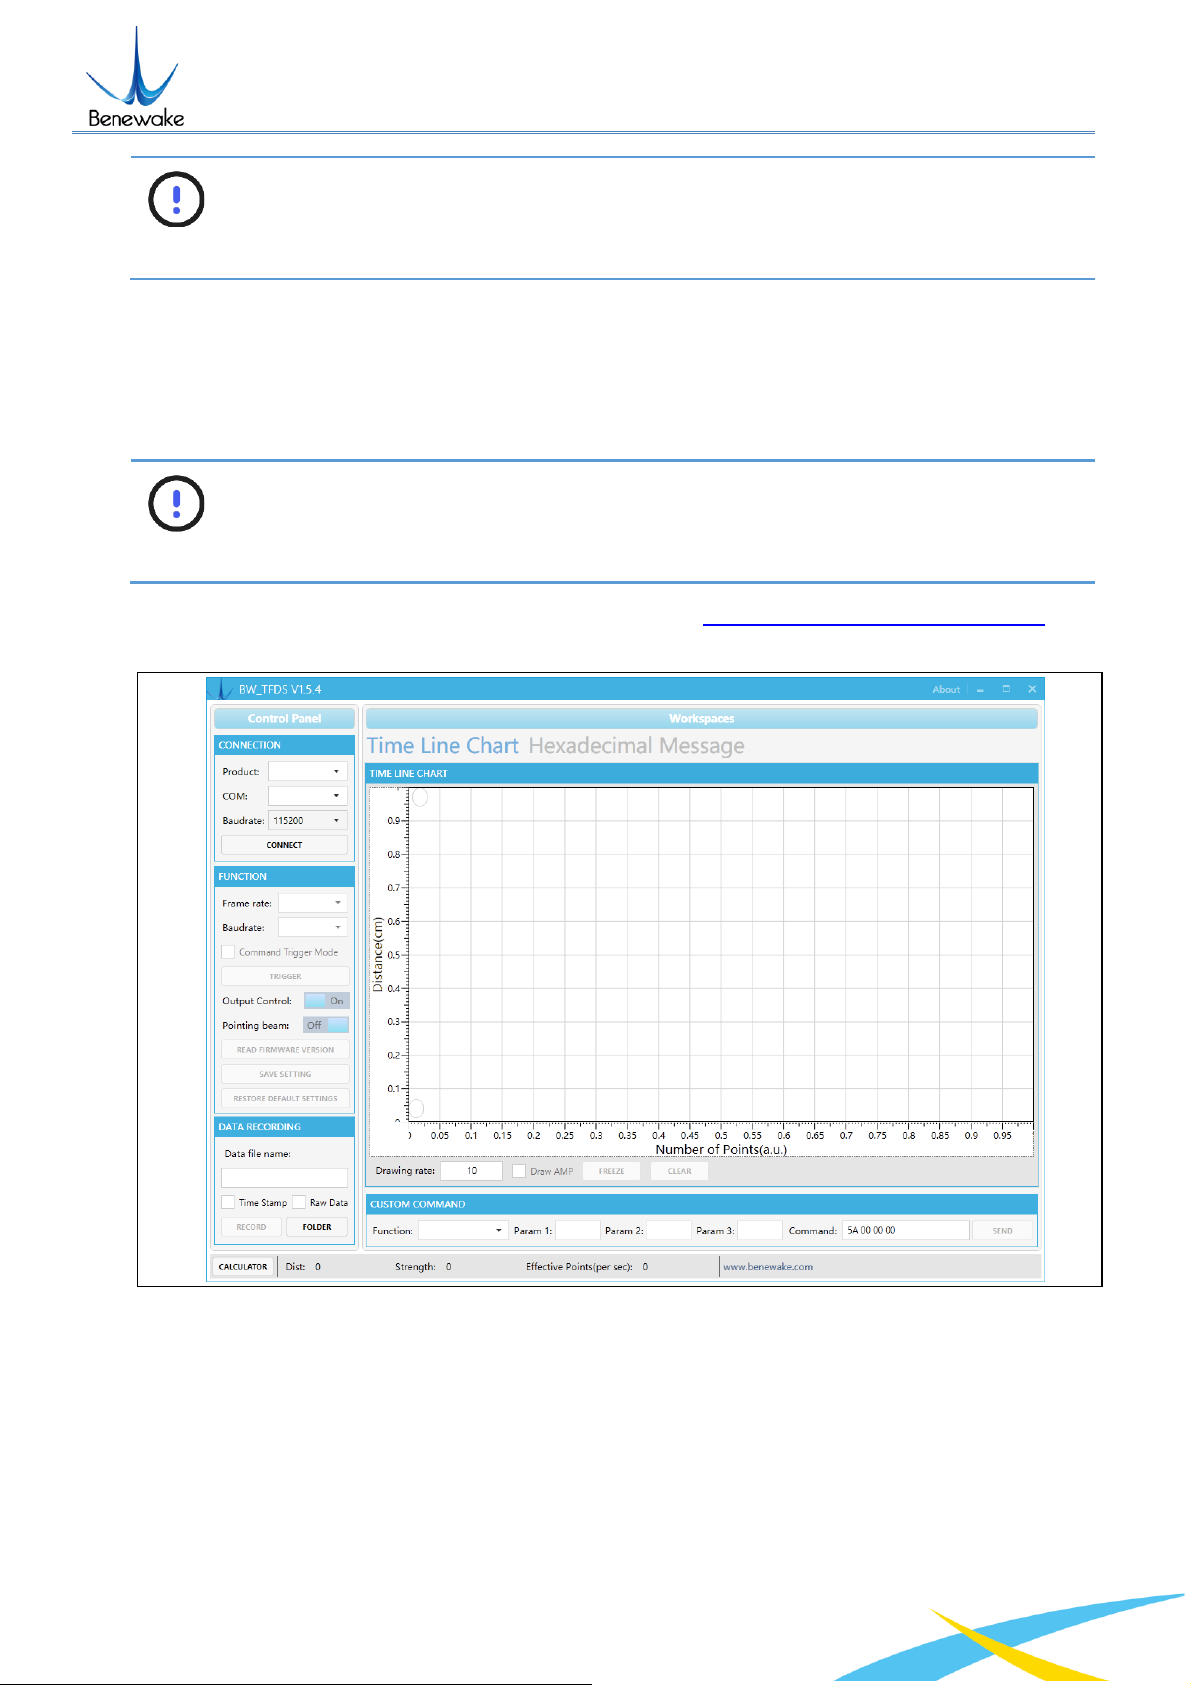
6.3 Extension cord
For testing purposes, we prepared an extension Dupont cord. See Figure 16 Extension
cord for test for detailed information.
Figure 16 Extension cord for test
Page 22
TF03 UART/CAN User Manual
QUICK START GUIDE
Page22 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
NOTE
This extension cord is free, but it’s not a standard accessory. Please contact us
if needed.
7 QUICK START GUIDE
7.1 Connection and basic test
NOTE
The product package contains only TF03 and factory certificate. If you need
USB converter, please contact our sales or technical support.
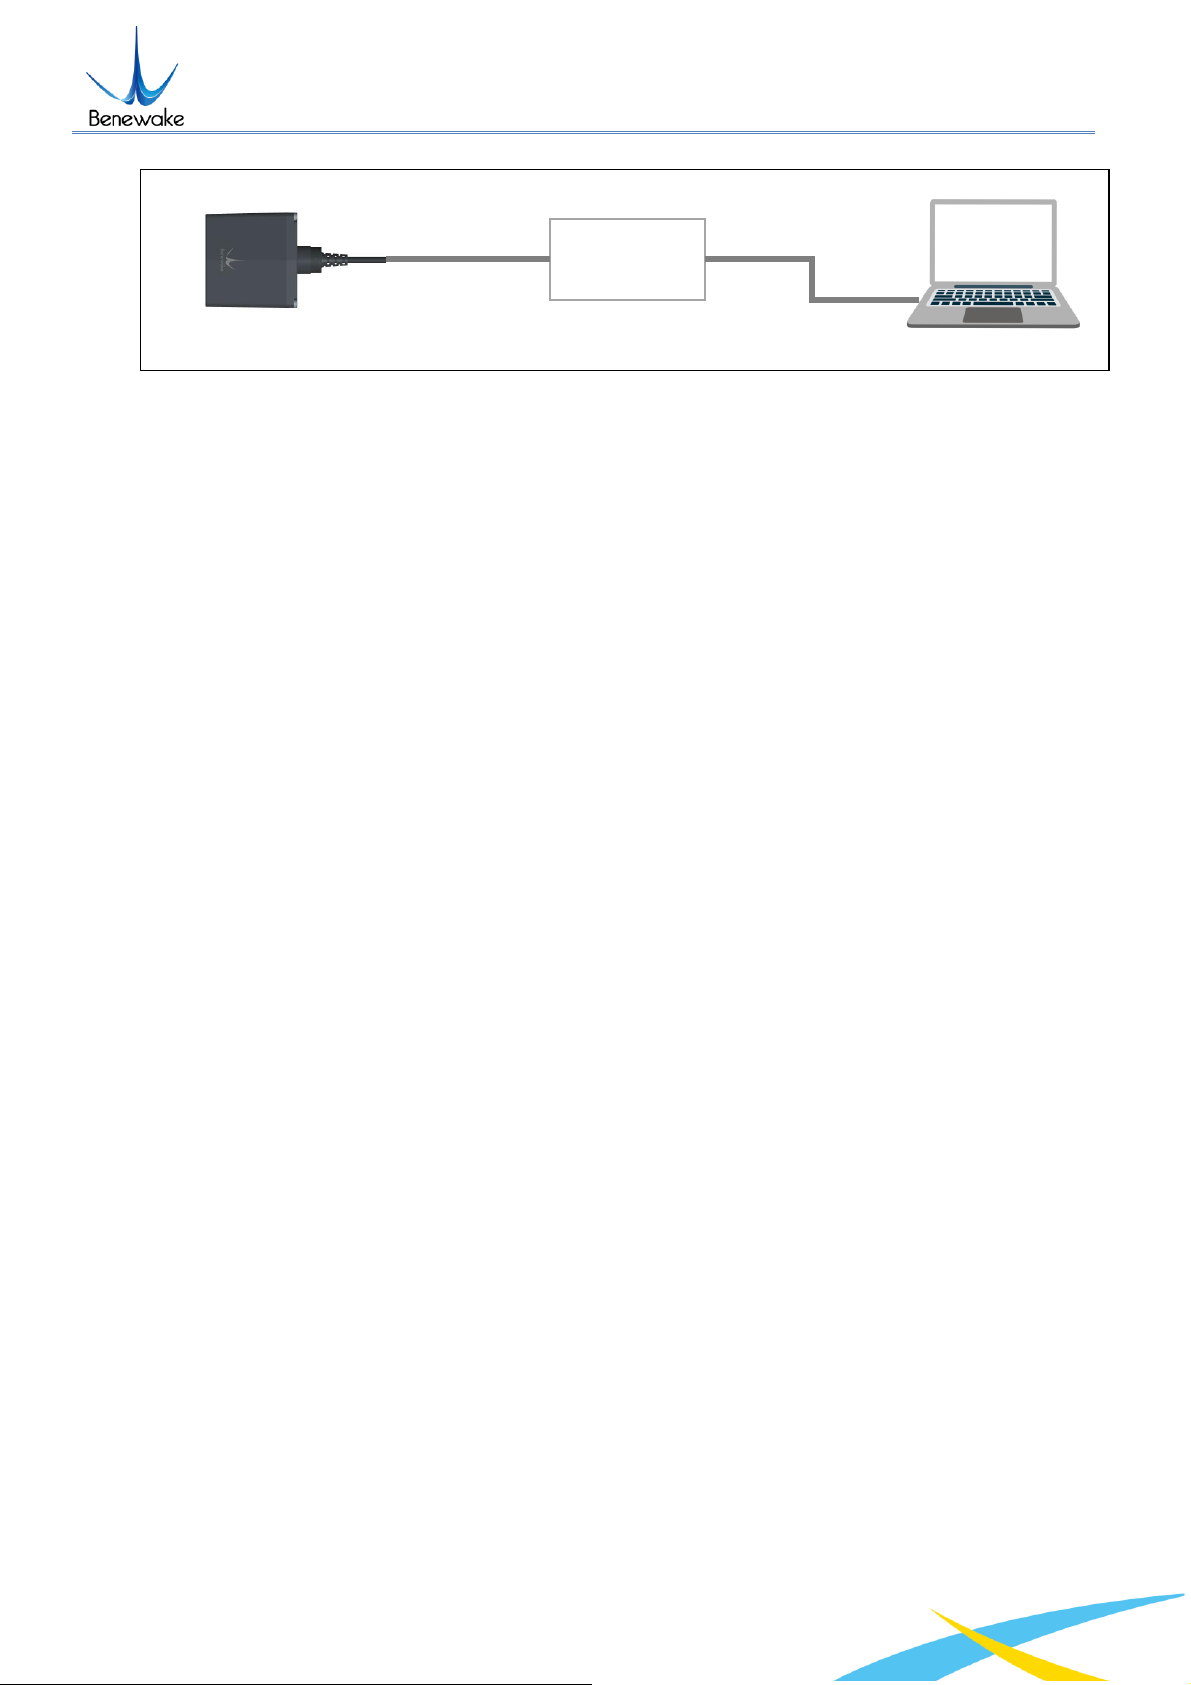
⚫ Download the latest version BW_TFDS from http://en.benewake.com/support onto
your PC or laptop.
⚫ See
错误!未找到引用源。
for of the GUI.
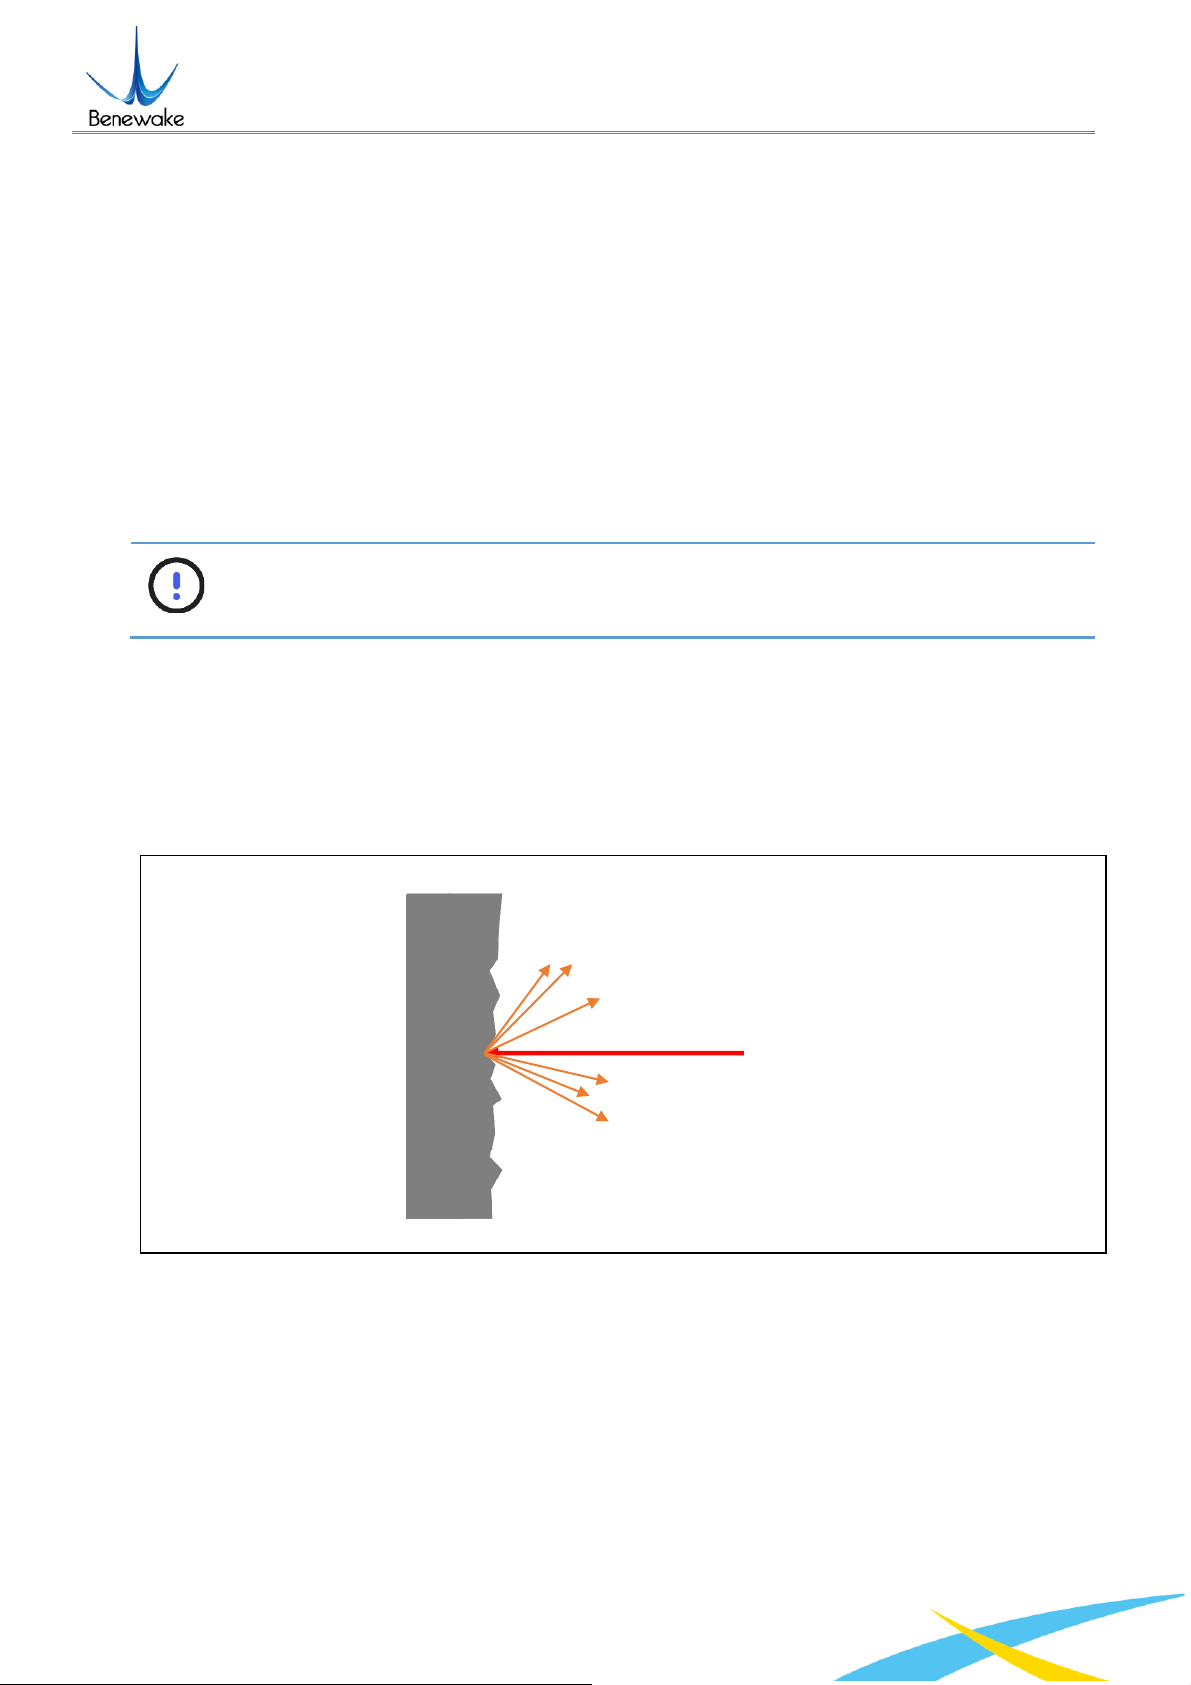
⚫ Connect TF03 to the PC or laptop with a paired USB converter cable as shown in
Figure 18 TF03 connecting to PC. The UART version TF03 needs a UART-USB
converter, and the CAN version TF03 needs a CAN-USB converter.
Figure 17 Benewake testing GUI for TF series
Page 23
TF03 UART/CAN User Manual
QUICK START GUIDE
Page23 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
Figure 18 TF03 connecting to PC
⚫ Run BW_TFDS.exe, choose the right baud rate and communication port, and click
CONNECT to start the test.
7.2 Troubleshooting guide for initial test
In the default working mode, TF03 will automatically output data when connected to the PC
following 7.1Connection and basic test. If you cannot read data from GUI properly, follow
these steps to locate and solve problems.
S1. Check if there is red light inside TF03 through its window.
◼ No. Check power supply. If the power supply is normal, please contact Benewake
service.
◼ Yes. Proceed to S2.
S2. Check whether the USB converter is paired with TF03. For example, TF03-100 CAN
needs a USB-CAN converter.
◼ No. Change a paired USB converter then try again.
◼ Yes. Proceed to S3.
S3. Check signal wiring. See 3.4 Wiring the UART Interface and 3.5 Wiring the CAN
Interface for detailed wiring information.
◼ Incorrect. Fix wiring.
◼ Correct. Proceed to S4.
S4. Some USB converters can generate more than one COM port. Try to connect
through different COM port.
◼ If all the COM ports don’t have data output, proceed to S5.
S5. Send the command of reading firmware version, 5A 04 01 5F, through every COM
ports. Try to read response.
◼ If all the COM ports have no response, please contact Benewake service.
◼ If one of the COM ports has correct response, send the command of restore
default, 5A 04 10 6E, through this COM port. After sending this command, if the
TF03 still doesn’t work, please contact Benewake service.
Interface
converter
Page 24
TF03 UART/CAN User Manual
QUICK START GUIDE
Page24 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
7.3 Working mode
TF03 has three different working modes.
⚫ Automatic output mode. This is the default working mode. The default frame rate of this
mode is 10Hz.
⚫ Command triggering mode. In this mode, TF03 will not output data automatically. TF03
output measuring data only when it receives the triggering command.
⚫ Low power consumption mode. In this mode, TF03 still output measuring data
automatically. But the maximum frame rate has been restricted to 5Hz. Meanwhile its
power consumption is reduced to 150mW.
NOTE
Only the UART interface supports low power consumption mode.
7.4 Influences of object surfaces on the measurement
The signal received from a perfectly diffuse reflecting white surface corresponds to the
definition of a remission of 100%. As a result of this definition, the remissions for surfaces
that reflect the light bundled (mirrored surfaces, reflectors), are more than 100%.
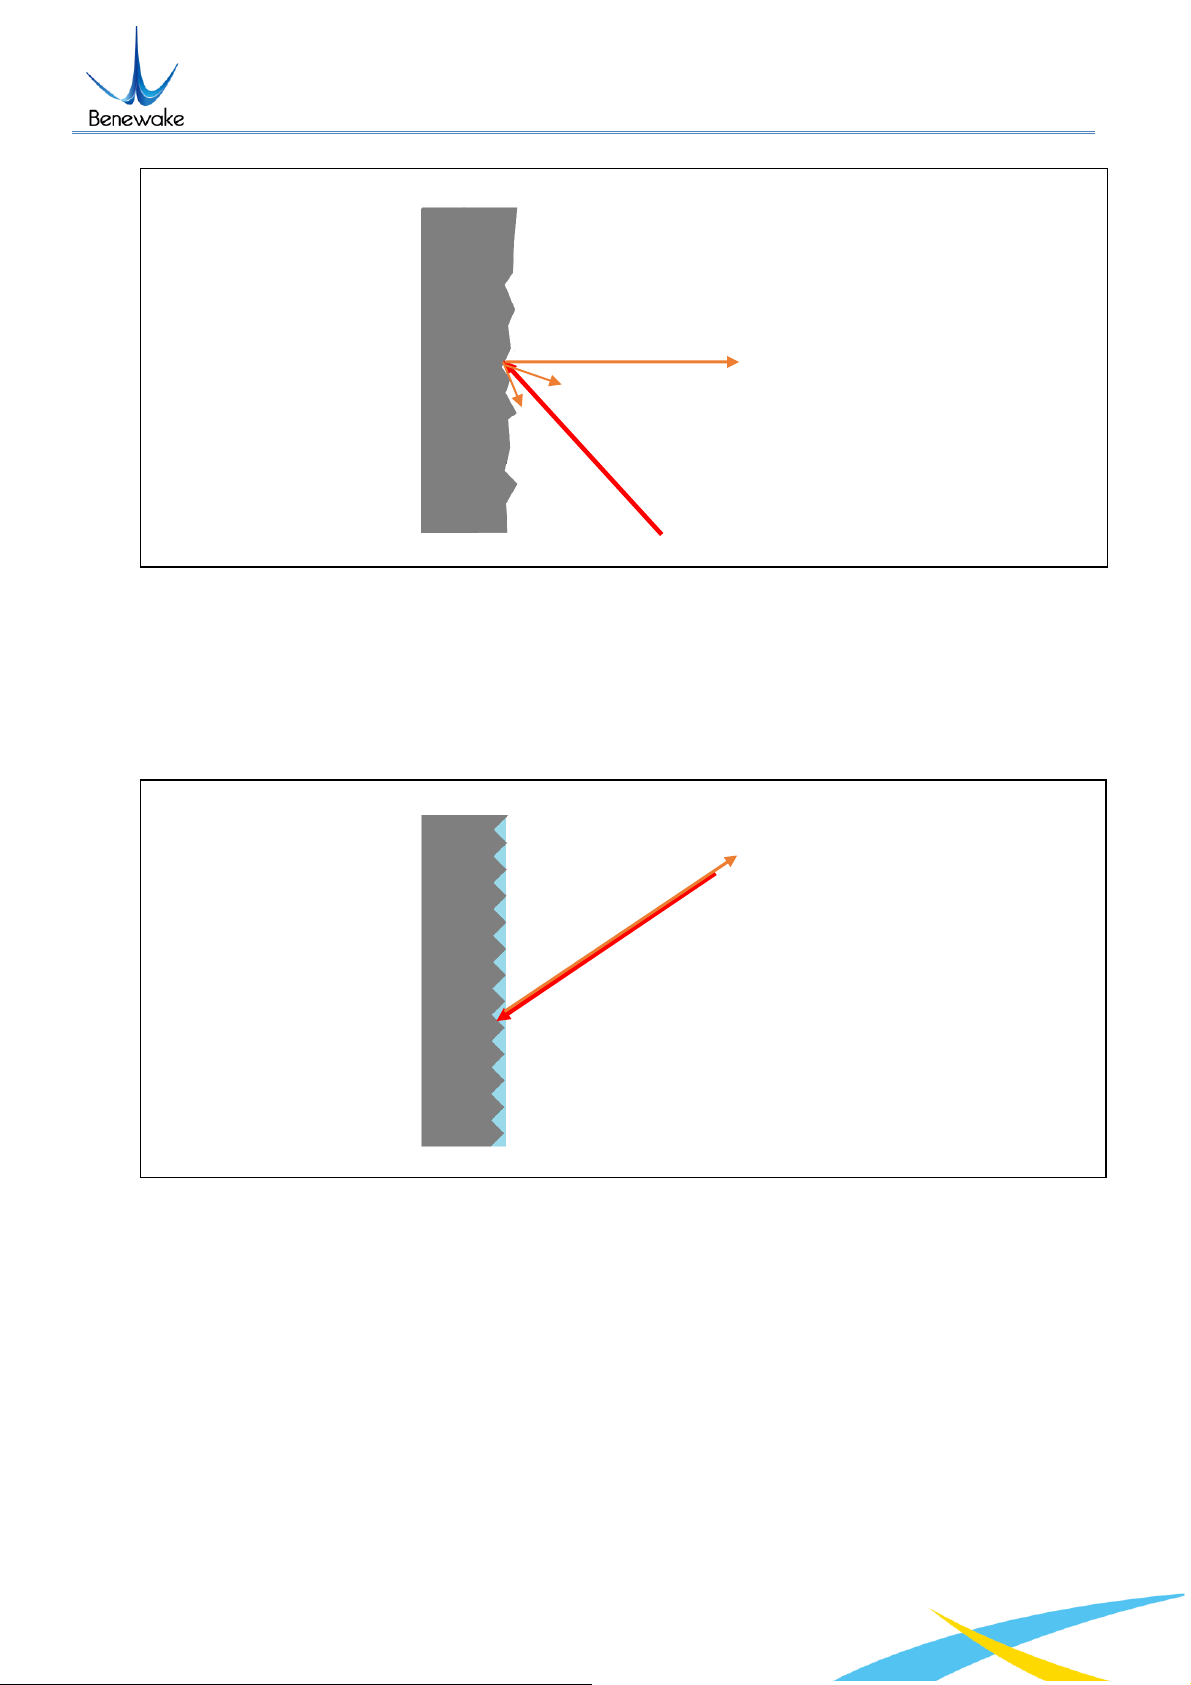
Figure 19 Reflection of the laser beam at the surface of an object
The majority of surfaces reflect the laser beam diffusely in all directions.
The reflection of the laser beam will vary as a function of the surface structure and color.
Light surfaces reflect the laser beam better than dark surfaces and can be detected by the
TF03 over larger distances. Brilliant white plaster reflects approx. 100% of the incident light,
black foam rubber approx. 2.4%. On very rough surfaces, part of the energy is lost due to
shading. The detecting range of the TF03 will be reduced as a result.
Page 25
TF03 UART/CAN User Manual
QUICK START GUIDE
Page25 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
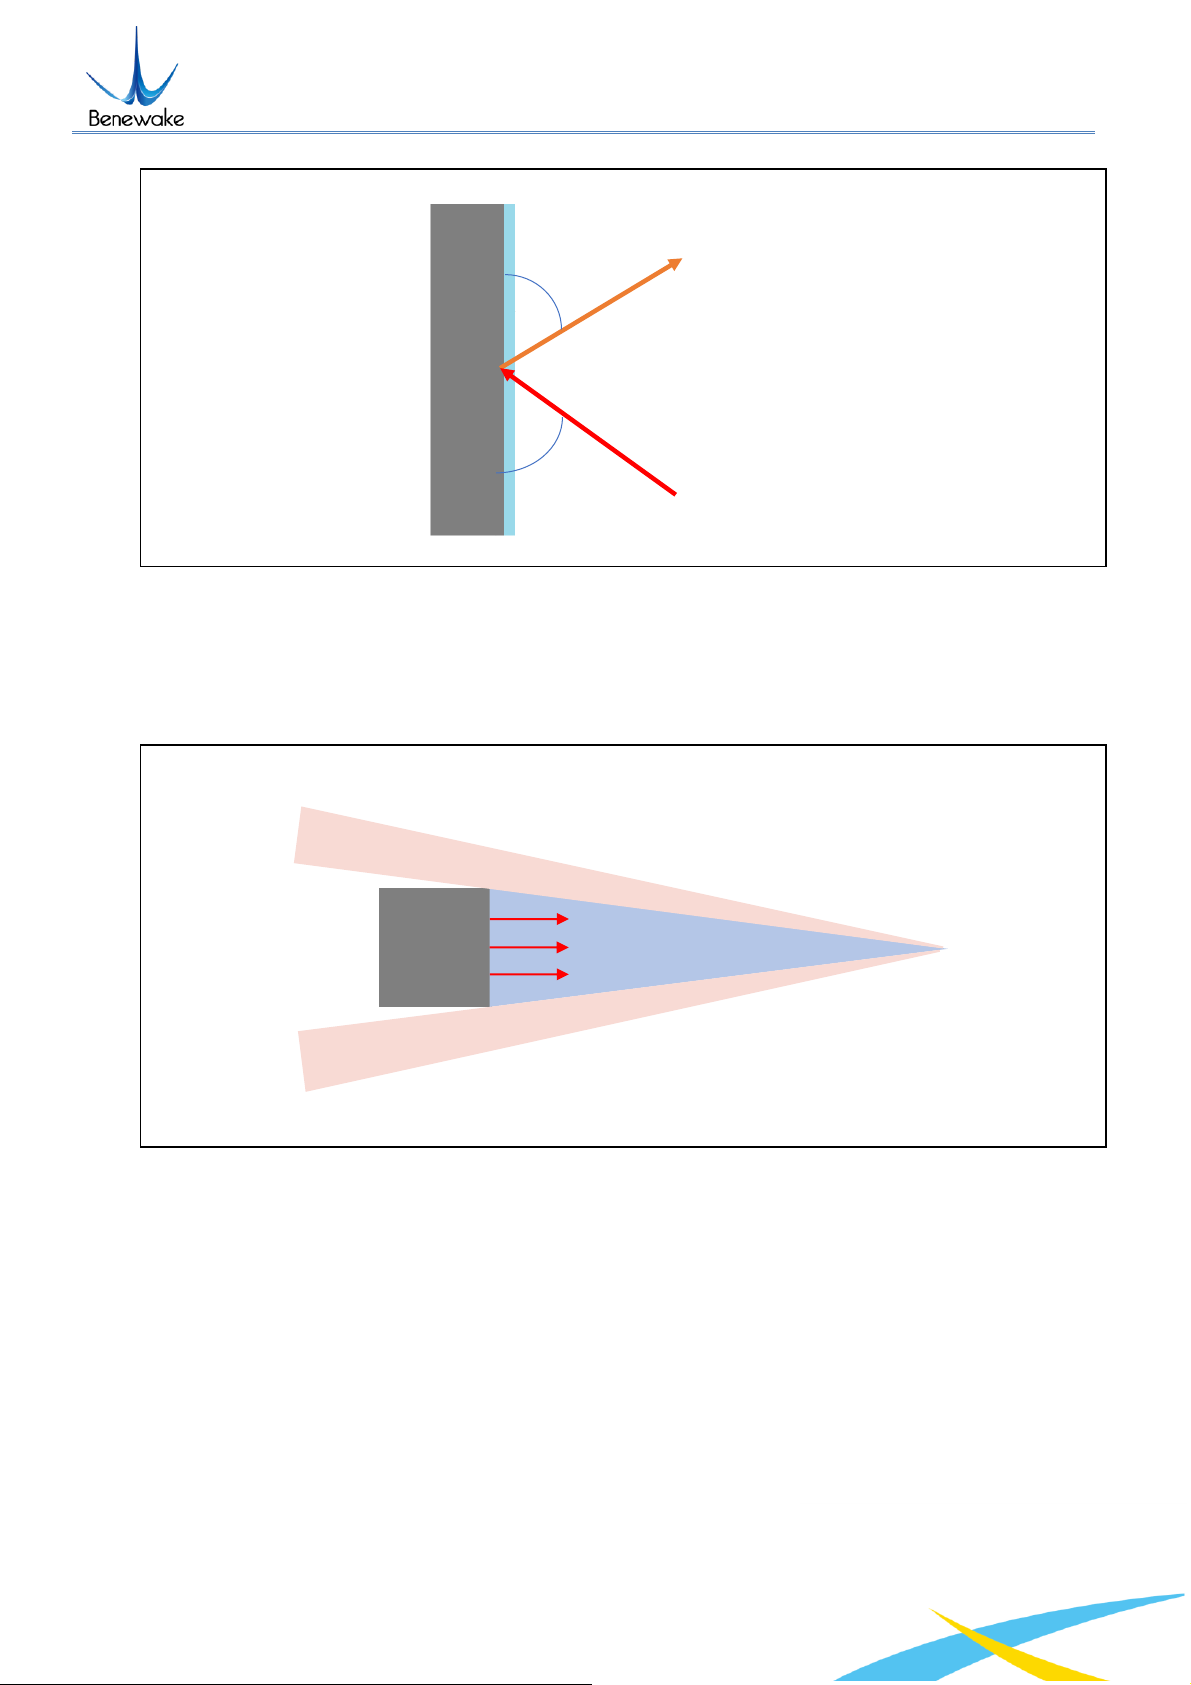
Figure 20 Reflection angle
The reflection angle is the same as the angle of incidence. If the laser beam is incident
perpendicularly on a surface, the energy is optimally reflected (Figure 20 Reflection angle
on page 25). If the beam is incident at an angle, a corresponding energy and detecting
range loss is incurred.
Figure 21 Degree of reflection
If the reflected energy returned is over 100% (basis: Kodak standard) the incident beam is
not reflected diffusely in all directions, but is reflected in a specific direction. As a result, a
large portion of the energy emitted can be received by the laser distance measurement
device. Plastic reflectors (“cats’ eyes”), reflective tape and triple prisms have these
properties.
Page 26
TF03 UART/CAN User Manual
QUICK START GUIDE
Page26 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
Figure 22 Mirror surfaces
At mirror surfaces the laser beam is almost entirely deflected (Figure 22 Mirror surfaces on
page 26). Instead of the surface of the mirror, it is possible that the object on which the
deflected laser beam is incident may be detected.
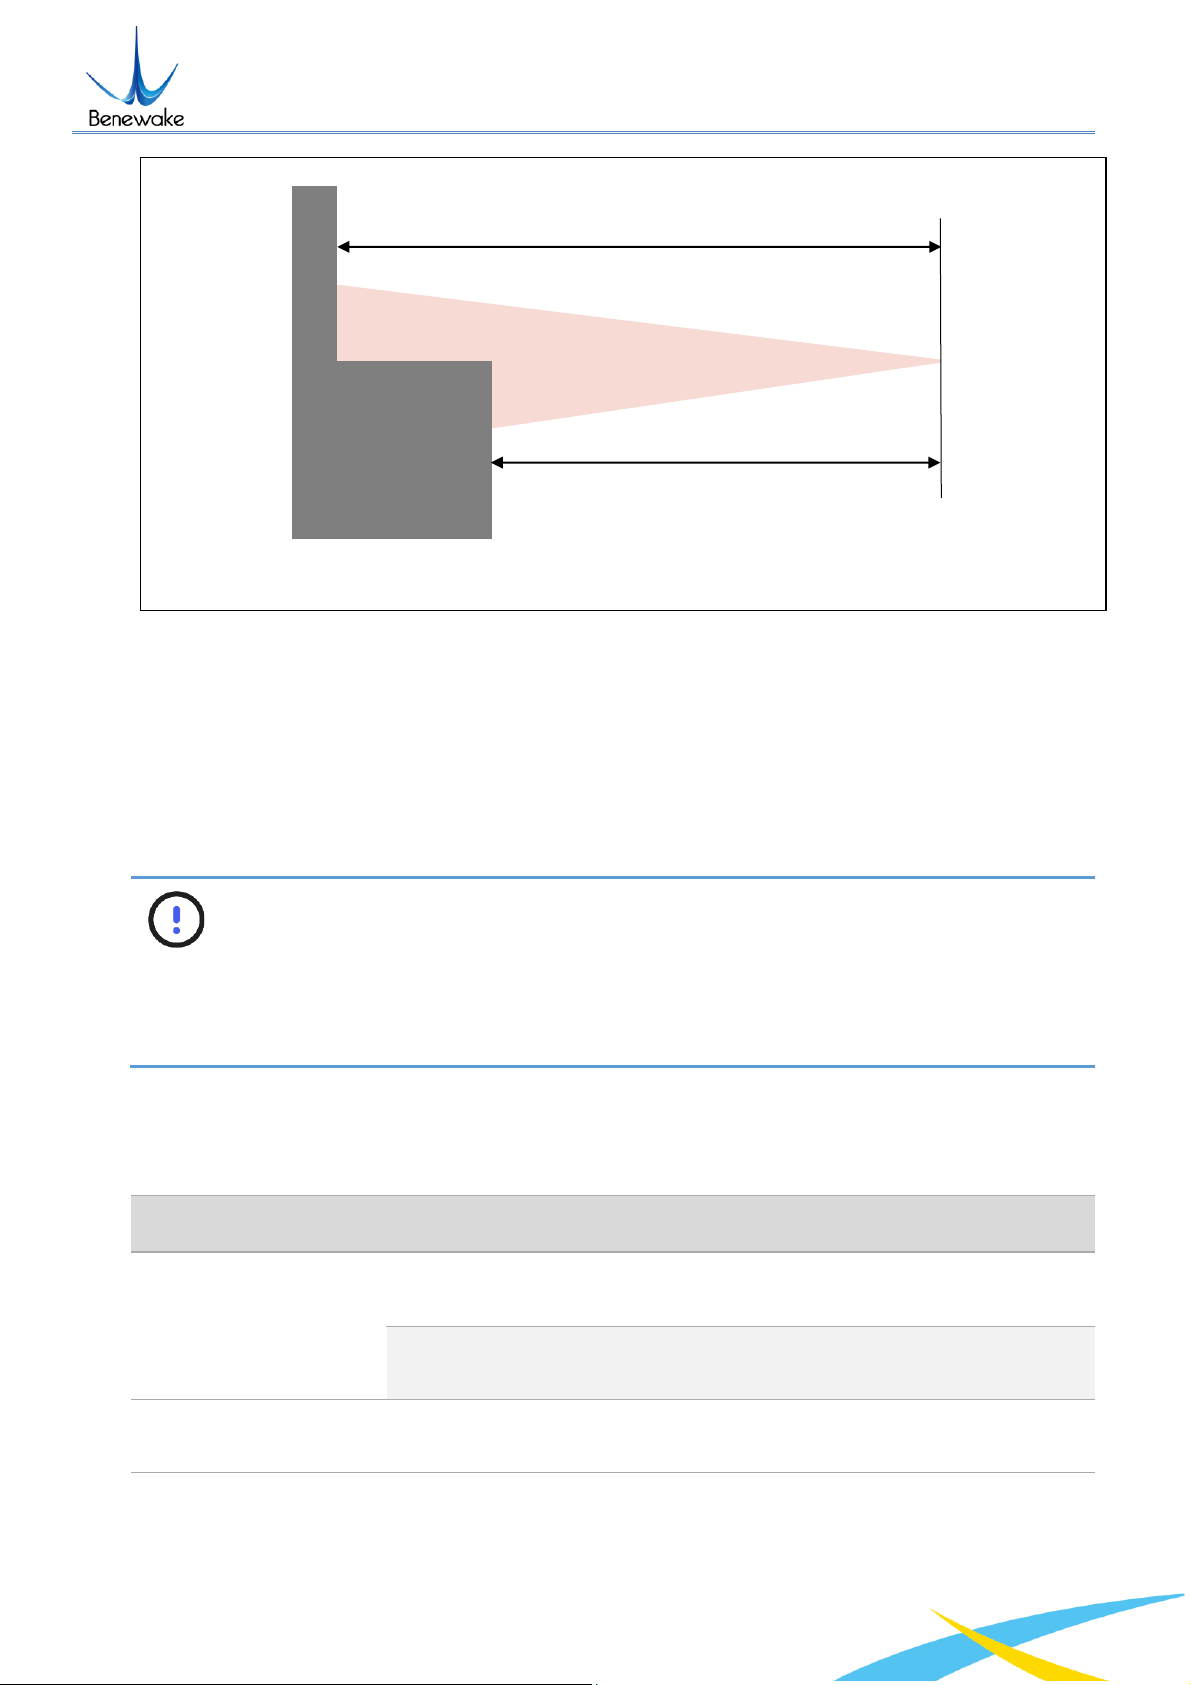
Figure 23 Object smaller than diameter of the laser beam
Objects that are smaller than the diameter of the laser beam cannot reflect all the energy
of the laser light (Figure 23 Object smaller than diameter of the laser beam on page 26).
The energy in the portion of the laser light that is not reflected is lost. This means that the
detecting range is less than would be possible theoretically based on the surface of the
object.
α
α
Page 27
TF03 UART/CAN User Manual
TROUBLESHOOTING
Page27 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
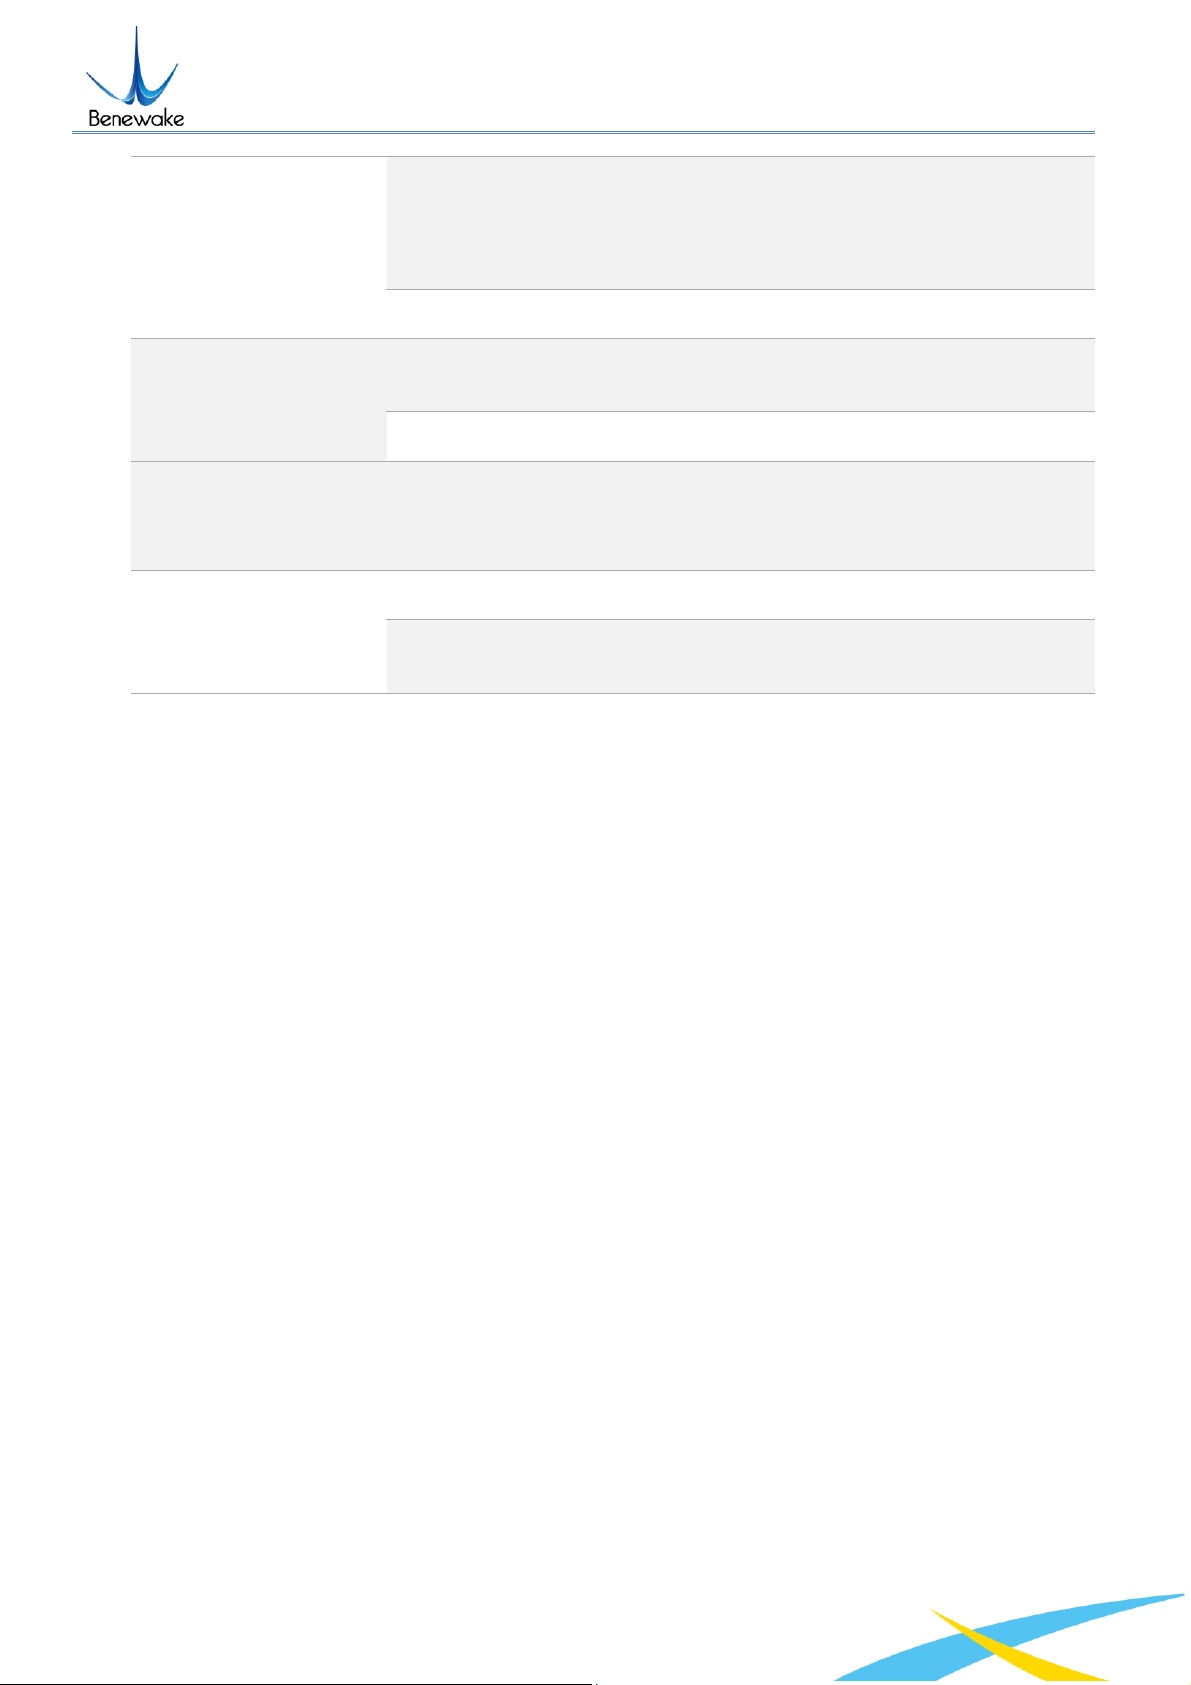
Figure 24 Staircase object
Staircase objects have two or more planes (Figure 24 Staircase object on page 27). The
energy in the portion of the laser light that is reflected by different plane is different. TF03
will calculate a weighted averaging energy. The measured value will possible theoretically
be the weighted average of distances from TF03 to different platform.
8 TROUBLESHOOTING
NOTICE
Claims under the warranty rendered void!
The housing screws of the TF03 are sealed. Claims under the warranty against
Benewake will be rendered void if the seals are damaged or the device opened.
s
This chapter describes how to identify and rectify errors and malfunctions during the
operation of TF03.
Table 11 Troubleshooting and rectification
Fault
Possible cause
Solution
Measurement exceeds
the allowed error.
⚫ Optical signal was blocked.
➢ Remove the obstacle or adjust the
detecting direction.
⚫ The target is a low
reflectivity object.
➢ Paste a reflector on target object.
Measurements in the
near range with no
⚫ Protective film has not
been removed.
➢ Remove the protective film.
Page 28
TF03 UART/CAN User Manual
TROUBLESHOOTING
Page28 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
measurement target.
⚫ Contaminated or scratched
window.
➢ Carefully clean optics using soft,
fluff-free cloth.
➢ If the optics are scratched, contact
Benewake service.
⚫ Rain or fog
➢ Enable rain-fog filter
TF03 is not transmitting
a measured result.
⚫ Wiring fault in the data
connection.
➢ Check wiring.
⚫ Wrong USB converter.
➢ Check USB converter.
Data transmitted is
garbage.
⚫ Baud rate mismatch.
➢ Check baud rate of the receiving
device.
➢ Check TF03’s baud rate setting.
A certain target cannot
be detected
⚫ The target is too small.
➢ Replace it with a larger target.
⚫ The target is a low-
reflectivity object.
➢ Put a sticker of high reflectivity on
target object.
Page 29
TF03 UART/CAN User Manual
ATTACHMENT 1: REFLECTIVITY OF
DIFFERENT MATERIALS
Page29 ©Benewake · All rights reserved · Subject to change without notice · 2021-08-09
ATTACHMENT 1: REFLECTIVITY OF DIFFERENT MATERIALS
The reflectivity of different materials is listed below, ranging from low to high. According to
the test target and the corresponding reflectivity, we can measure whether the range of
TF03 and other parameters meet the requirements.
No.
Materials
Reflectivity
1
black foam rubber
2.4%
2
black cloth
3%
3
black rubber
4% 4 Coal (varies from coal to coal)
4~8%
5
Black car paint
5%
6
Black paper
10%
7
opaque black plastic
14%
8
Clean rough board
20%
9
newspapers
55%
10
translucent plastic bottles
62%
11
packing case cardboard
68%
12
Clean pine
70%
13
opaque white plastic
87%
14
white card
90%
15
Kodak standard whiteboard
100%
16
Unpolished white metal surface
130%
17
Shiny light metal surface
150%
18
stainless steel
200%
19
Reflective board, reflective adhesive tape
>300%
 Loading...