

Page 1
Distributor
CTB technology
BEIJING CTB TECHNOLOGY CO., LTD.
Address: Wanggezhuang Industry Base, Shilipu Town, Miyun County,
Beijing
Tel.: 010 -82755611
Fax: 010 -82755610
24-hour national free service Tel.:400 -888-9055
Data No.: ZL-12-808-IBCN
The data may subject to change without notice as improvement of the
product.
Page 2
CTB technology
GS DRIVER
P100 operating manual
AC servo spindle driver
Model: BKSC-□ □ □ □ GS □
Class 400V, 1.5 ~ 315KW (2.5 ~ 460KVA)
Please send the manual to final user, and keep it properly.
BEIJING CTB TECHNOLOGY CO.,LTD.
Data No.: Z L-12-808-I B C N
Page 3
GS DRIVER CTB
Preface
Thank you for purchasing GS series servo driver produced by Beijing CTB Technology Co.,
Ltd. The GS series AC servo spindle driver is a high-quality, multi-functional and low-noise
AC servo driver that was researched, developed and manufactured by Beijing CTB
Technology Co., Ltd. The spindle driver is servo driver for AC induction motor (IM) and AC
permanent magnet synchronous motor (PM). It can control the position, speed,
acceleration and output torque of various AC servo spindle motor appropriately. The wide
application of GS series AC servo spindle driver brings infinite vitality to field of machine
tool spindle drive control.
In command to achieve control functions of various machine tools, GS series AC servo
spindle driver is equipped with dual 32-bit CPU and abundant control function module. It
may be conveniently connected with various domestic and foreign CNC systems through
standard control interfaces to allow full play to spindle function of CNC system. The
characteristics of torque, acceleration and deceleration, precision and efficiency of machine
tool spindle which is equipped with GS series AC servo spindle driver are remarkable, and
accurate stop, C-axis, rigid tapping, electronic shift, multi-axis synchronization and other
spindle functions can be realized easily. GS series AC servo spindle driver is the first
choice of electric spindle drive products.
As the first choice of driving product of various machine tool power shaft (spindle), GS
series AC servo spindle driver can be widely used for spindle drive of product such as CNC
milling machine, vertical machining center, horizontal machining center, CNC boring
machine, CNC lathe, vertical lathe, heavy horizontal lathe and gantry machine tool.
For proper application, please read the manual carefully before using the GS series AC
servo spindle driver. Abnormal operation, fault or reduction of service life, and even
personal injury accident may be caused by inappropriate use. Therefore, the manual shall
be read repeatedly before use, and operate in strict accordance with the instructions. The
manual is attachment with the equipment. Please keep it properly after using for future
repair and maintenance of the driver.
01
Page 4
GS DRIVER CTB
Safety -related symbol description
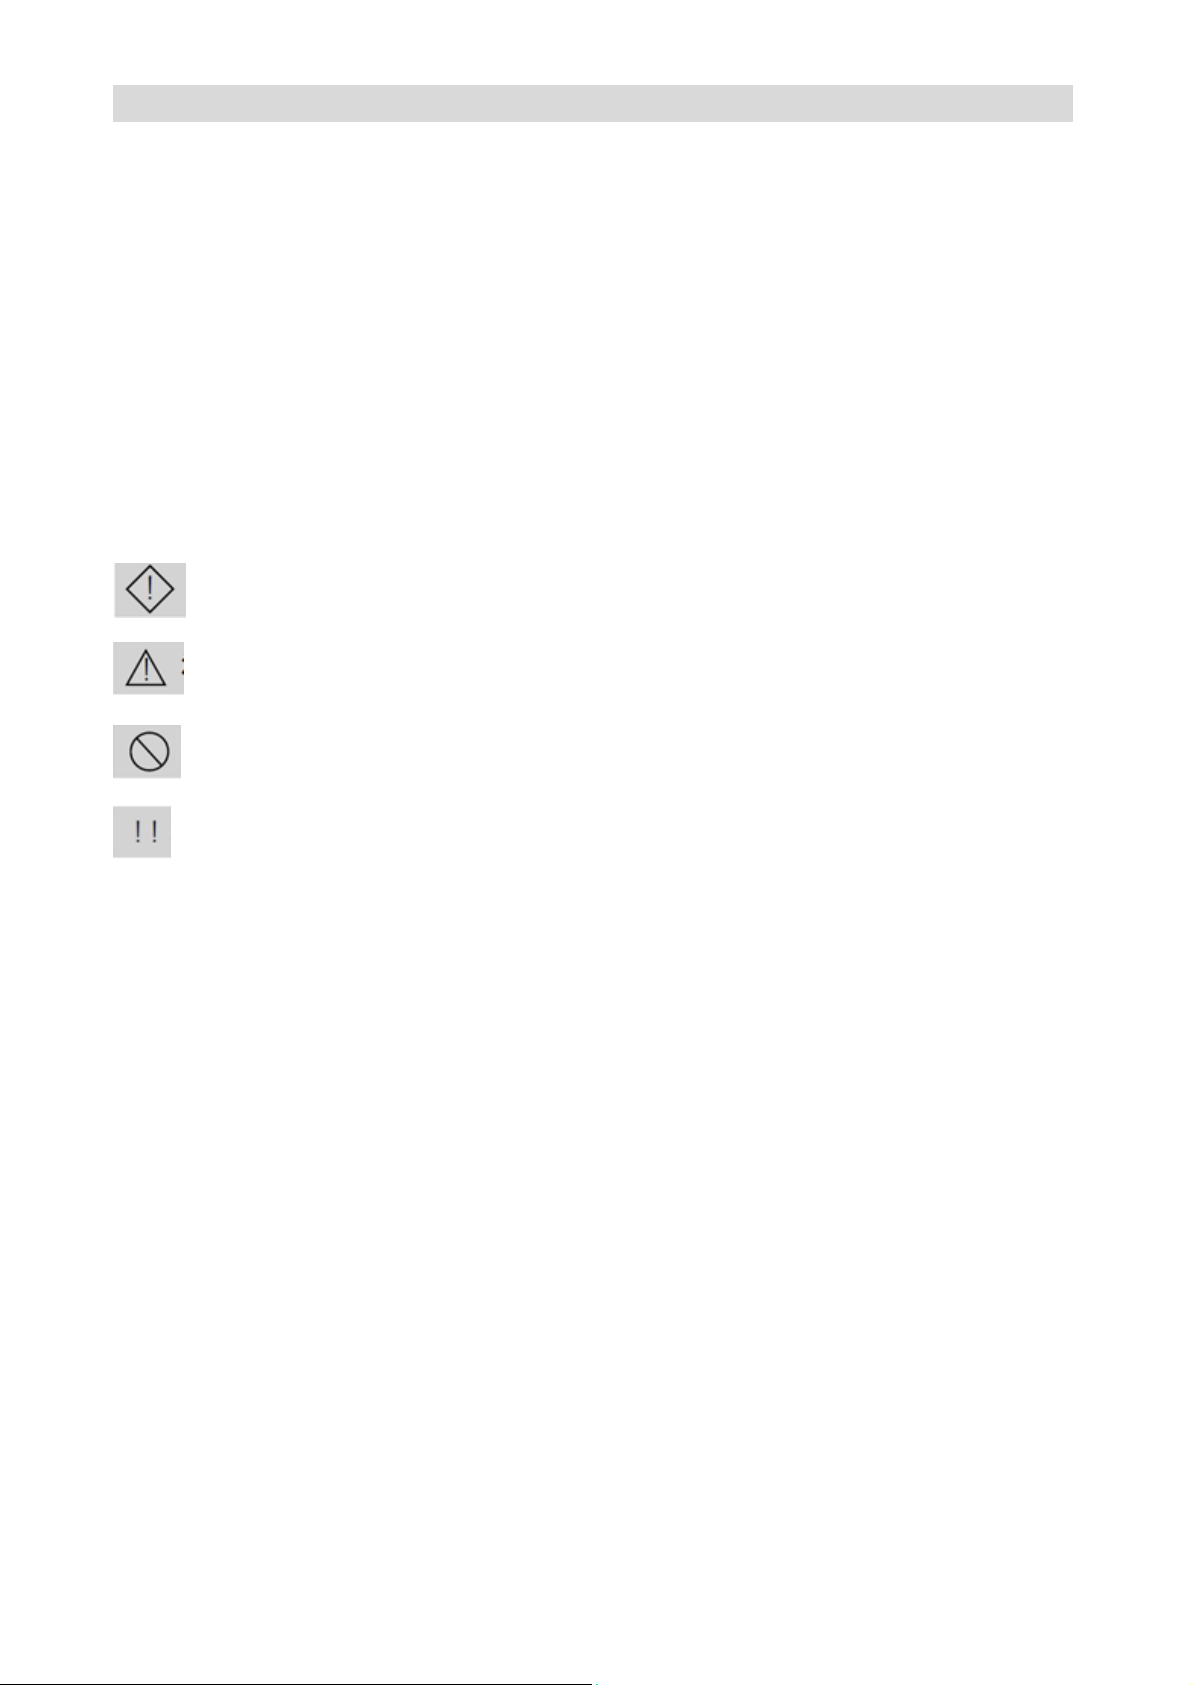
The following symbols are used for safety-related content in the manual. Sentences
marked by the safety symbols describes important content, and must be abided. If the
requirements in the safety-related content are not abided, application of the product may
led to abnormal product operation, damage to the product, even danger and personal
injury.
Danger
Caution
Forbid Prohibited matters (matters that cannot do).
Important
Use the symbol where danger, even personal injury or death when
wrong about the described content.
Use the symbol where danger, even mild or moderate personal
injury and equipment damage when wrong about the described
content.
Certain matters do not belong to "danger", and "caution", but they
are required to be abided by user. They are marked in the relevant
sections.
02
Page 5
GS DRIVER CTB
Safety precautions
◆ Unpacking inspection
Caution
● For risk of injury, please do not install damaged or part missing driver.
◆ Installation
Caution
● For risk of fire, please install the equipment on nonflammable metal plate without
combustible materials around.
● Please be sure to tighten the mounting screws of the driver. Falling and damage of the
driver or personal injury may be caused by mounting screws loosing.
●Please do not install the equipment in environment with flammable gas where an
explosion is caused easily.
◆ Wiring
Danger
● For risk of electric shock and fire, please make sure that the input power supply is in
the OFF state before wiring.
●For risk of electric shock, the operation on main circuit terminal of the controller shall be
conducted after the power is cut off for five minutes, and the power charge indicator
CHARGE in the controller completely extinguished.
●For risk of electric shock and fire, the wiring shall be carried by professional electrical
engineering personnel.
●For risk of electric shock and fire, the ground terminal must be grounded reliably. (earth
resistance shall be lower than 4Ω)
● It's prohibited to directly connect terminals of P / PB and N, or connect the zero line or
the earth wire to the N terminal. Otherwise, the rectifier bridge will be shorted and the
main loop will be burned.
●It's prohibited to connect the high-voltage line to control terminal of the driver.
Otherwise, the control board will be burned.
●For risk of injury, please set emergency stop and locking circuit at the outside of the
controller (user is responsible for the wiring) .
● There is a risk of electric shock and short circuit.
03
Page 6
GS DRIVER CTB
◆ Wiring
Caution
●For risk of injury and fire, please ensure that the voltage of the main circuit AC input
power and the rated voltage of the driver are consistent.
● Please do not conduct withstand voltage and insulation test to the controller
arbitrarily. Otherwise, the semiconductor and other components in the controller may
be damaged.
●For risk of fire, please connect braking resistor and braking unit according to the
wiring diagram.
● Please do not connect the AC input power cord to the output U, V, W terminals.
Otherwise, damage to inside of the controller may be caused.
●For risk of fire and malfunction of the controller, please tighten the terminals of main
loop and control circuit with appropriate torque.
●Please do not connect the phase shifting electrolytic capacitor and LC / RC noise
filter to the output circuit. Otherwise, damage to inside of the controller may be
caused.
●Please do not connect the electromagnetic switch and electromagnetic contactor to
the output circuit to connect or disconnect the load. During loaded operation of the
controller, the surge current will arose protection circuit action of the controller.
◆ Trial run
●For risk of electric shock and short circuit, please do not touch the terminals of the
main circuit directly after power-on.
●Please confirm the input and output signals to guarantee safe operation.
Malfunction of the system will cause casualties and damage to the work piece and
nearby equipment..
●For risk of injury, alarm reset only can be done after ensuring that the operating
Danger
04
signal is cut off. Alarm reset with operating signal will lead to suddenly re-start.
●For risk of driver burning, the inside of long term stored driver shall be checked for
water and condensation.
●For risk of electric shock and burning the equipment, it's prohibited to touch the
terminals of the driver with hand during operating.
Page 7
GS DRIVER CTB
Caution
●For risk of scalding, the running servo driver and motor may have a high
temperature rise, please do not touch.
●For risk of scalding and electric shock as the braking resistor has a high
temperature rise for discharging, please do not touch.
●For risk of damage to the equipment and accident, please do not change the
settings of the drive arbitrarily.
05
Page 8
GS DRIVER CTB
◆ Maintenance and inspection
Danger
●For risk of electric shock, please do not directly touch terminals of the controller.
Some of them have high voltage and very dangerous.
●For risk of electric shock, please do install the housing before power-on; and must
disconnect the power firstly before removing the housing.
●For risk of electric shock and fire, please confirm that the power source is in the OFF
state or not before wiring.
● Inspection and maintenance only can be carried out after cut off the main circuit input
power and confirm that the power charge indicator CHARGE completely extinguished.
There is a risk of electric shock as residual power in electrolytic capacitor.
●Please make designated professional electrical engineering personnel to conduct
inspection and maintenance. Before work, please take off metal object (watch, rings
etc.), and use tools with insulation protection during operation. Otherwise, it may cause
electric shock.
●For risk of explosion and fire, used battery, circuit printing plate must not be throw into
fire. Otherwise, it may cause explosion.
Caution
●CMOS IC integrated circuit is installed on main control panel. Full attention shall be
paid during operating. The electrostatic induction due to direct touching of finger on the
main control panel may cause damage to the main control panel.
●For risk of electric shock, please do not conduct wiring and removing terminal when
the equipment is energized.
●For risk of damage to the equipment, the appropriate parameter settings must be
carried out before running after control panel replacing.
06
Page 9

GS DRIVER CTB
Table of contents
Preface……………………………………………………………………………………………1
Safety -related symbol description…………………………………………………………..2
Safety precautions………………………………………………………………..……………..3
Chapter 1 - Installation…………………………………………..……………………………1-1
Introduction to GS DRIVER…………………………………..……………………………1-2
Unpacking inspection…………………………………………..……………………………1-2
Standard specifications and performance parameters…………………………………1-3
Driver nameplate description………………………………………………………………1-4
External dimensions and installation dimensions…………………………………………1-4
Confirmation and requirements of the installation space………………………………1-7
Notes on motor and load……………………………………………………………………1-7
Notes on the driver…………………………………………………………………………1-8
Notes on scrapping…………………………………………………………………………1-9
Chapter 2 – wiring…………………………………………………………………………….2-1
Selection and connection of peripheral devices…………………………………………2-2
Wiring of the main circuit terminals………………………………………………………2-3
Wiring of control circuit ……………………………………………………………………2-10
Connection of the encoder interface……………………………………………………2-15
Connection of the serial communication port ……………………………………………2-16
Chapter 3 - Manipulator application……………………………………………………….3-1
0.4 ~ 18.5kw driver:
Configuration and key functions of the manipulator………………………………………3-2
Operative mode of the driver………………………………………………………………3-3
Operative mode of the manipulator………………………………………………………3-4
Use method of the manipulator……………………………………………………………3-5
Modify the parameters with the manipulator……………………………………………3-6
Monitor operating state with the manipulator……………………………………………3-7
22 ~ 315kw driver:
Configuration and key functions of the manipulator……………………………………3-8
07
Page 10
GS DRIVER CTB
Operative mode of the driver…………………………………….………………………3-10
Operative mode of the manipulator…………………………….………………………3-10
Use method of the manipulator………………………………….………………………3-12
Modify the parameters with the manipulator………………….………………………3-12
Monitor operating state with the manipulator……………….………………………3-13
Chapter 4 - Test run…………………………………………………………………..………..4-1
Basic procedure of test run…………………………………………………………………4-2
Confirmation of connection of the main circuit……………………………………………4-2
Control circuit wiring confirmation…………………………………………………………4-3
Initial power-on of the driver………………………………………………………………4-3
Motor and driver parameters confirmation………………………………………………4-4
No-load test run………………………………………………………………………………4-4
Loaded test run………………………………………………………………………………4-4
Chapter 5 - Parameter list……………………………………………………………………5-1
Parameter list description.............................................................................................5-2
Monitor parameter U1................................................................................................5-2
Monitor parameter U2..............................................................................................5-3
Monitor parameter U3..............................................................................................5-3
Initialize parameter An..............................................................................................5-3
Basic control parameter Bn..........................................................................................5-5
User parameter Cn.......................................................................................................5-6
Motor drive parameter Dn..........................................................................................5-8
Function parameter Fn.......... ........................................................................5-9
Function parameter In.................................................................................................5-9
Protection parameter Pn.............................................................................................5-10
System communication parameter Sn......................................................................5-11
Chapter 6 - Operation by function…………………………...………………………………6-1
Spindle control timing sequence state diagram…………………………………………6-2
Motor basic parameters setting……………………………………………………………6-2
Motor operating parameters……………………………………………………………..6-3
Operation panel operation……………………………………………………………..……6-3
Analog quantity speed control……………………………………………………………..6-3
08
Page 11
GS DRIVER CTB
Acceleration and deceleration control parameters………………………………………6-5
Accurate stop parameters………………………………………………………………6-6
Rigid tapping…………………………………………………………………………….. 6-7
PULSE control…………………………………………………………….. ………………6-8
Swing control…………………………………………………………….. …………………6-9
Multi-function terminal control……………………………………….. …………………6-10
Chapter 7 – Troubleshooting………………………………………………………………..7-1
List of fault alarm and remedies …………………………………………………………..7-2
Common fault analysis……………………………….……………………………………..7-3
Alarm reset method………………………………………………………………...………..7-7
Chapter 8 - Routine maintenance...................................................................................8-1
Prompt..........................................................................................................................8-2
Routine maintenance .................................................................................................8-2
Regular maintenance..................................................................................................8-3
Wearing parts of the driver ..........................................................................................8-3
Driver storage..............................................................................................................8-4
Driver warranty.............................................................................................................8-4
09
Page 12
GS DRIVER CTB
Installation
The chapter describes matters to be confirmed and installation requirements for the user
after getting the GS driver.
Introduction to GS DRIVER……………………………………….1-2
Unpacking inspection………………………………………………1-2
Standard specifications and performance parameters…………1-3
Driver nameplate description……………………….……………..1-4
External dimensions and installation dimensions.………..……..1-4
Confirmation and requirements of the installation space.……....1-7
Notes on motor and load…………………………….……………..1-7
Notes on the driver…………………………….……………….…..1-8
Notes on scrapping………………………….………………….…..1-9
Page 13
GS DRIVER CTB
Introduction to GS DRIVER
GS DRIVER is a type of spindle driver that specifically designed for CNC machine tool.
Precise control of position, speed, acceleration and output torque of AC induction servo
motor and ordinary inverter motor is allowed through the driver. It can be used for control of
spindle motor of machining center, CNC milling machine, CNC drilling machine, CNC lathe,
CNC grinder, and feed motor of large gantry equipment and vertical lathe. To achieve the
best operation effect, please complete wiring with CNC system by the " CTB servo
application manual ", and carry out installation and commissioning in accordance to the
manual.
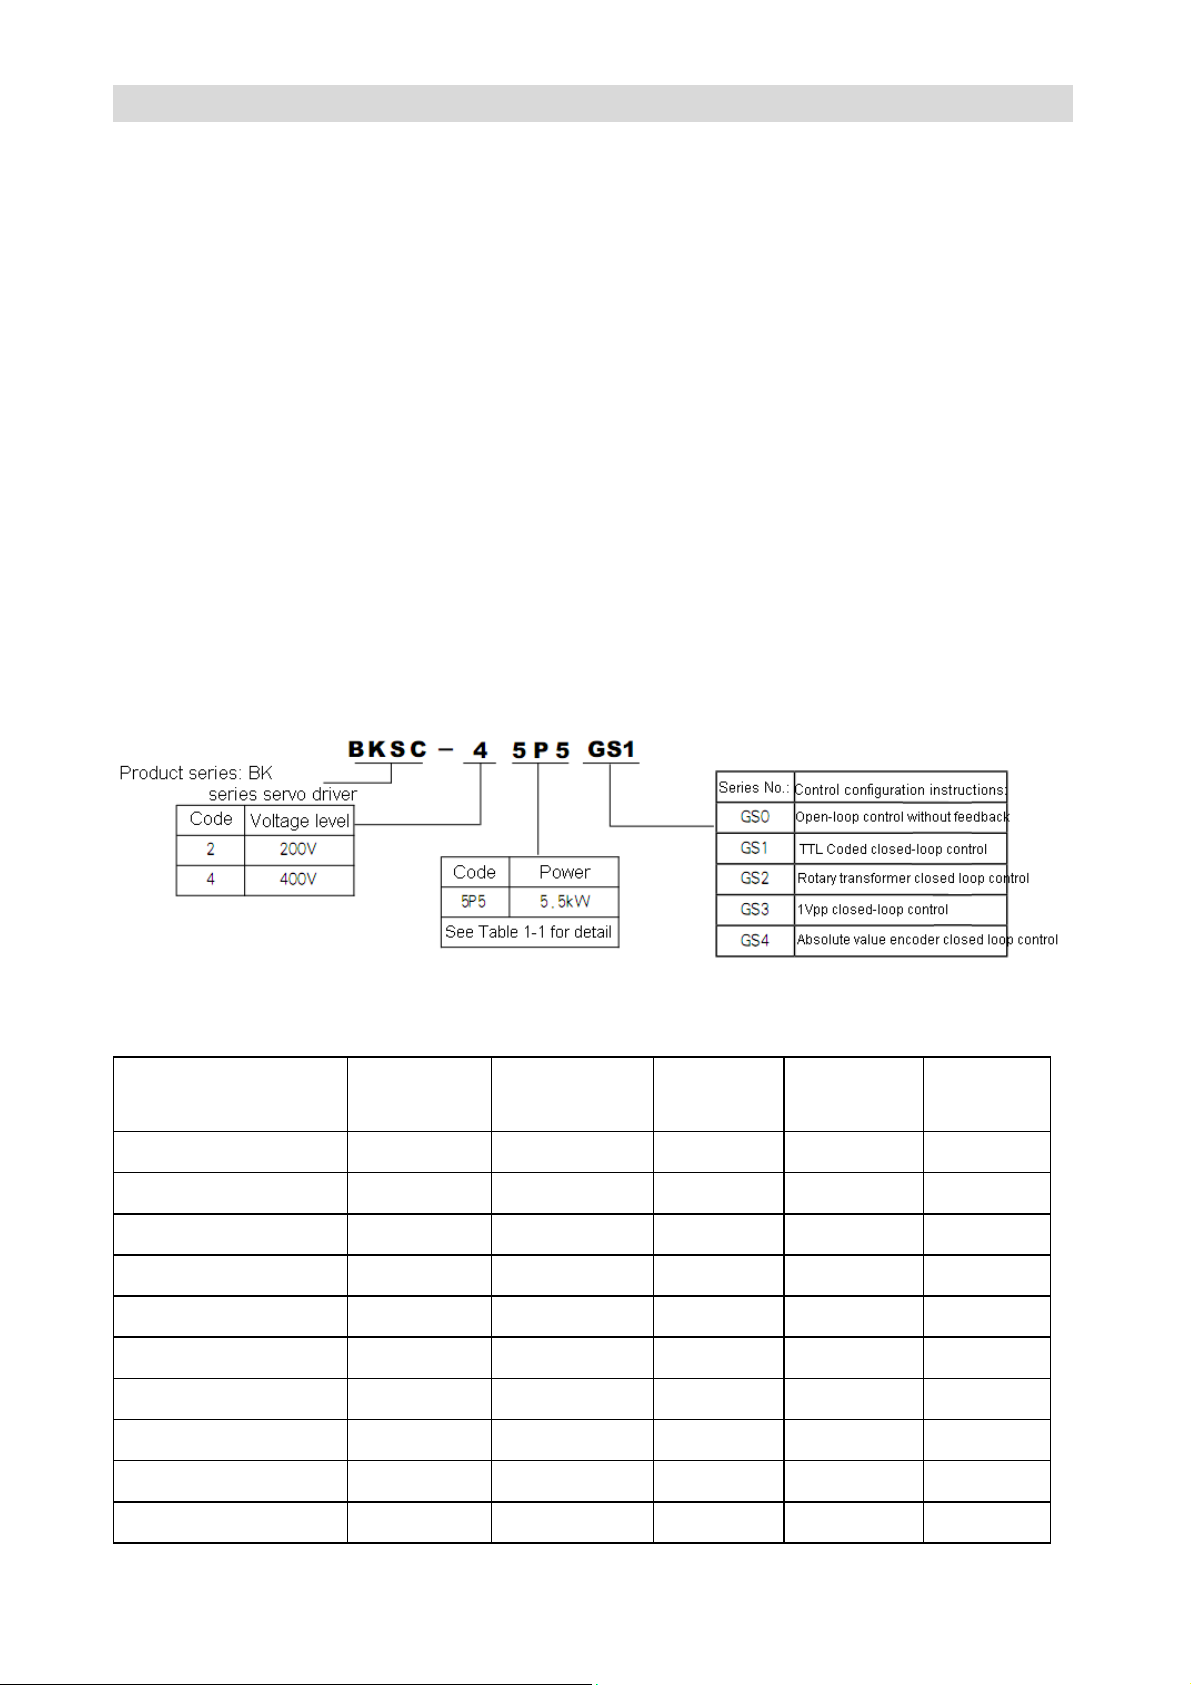
Model description
● GS driver series servo driver is suitable for motor with capacity from 1.5 to 315kw. Please
see the 21 models shown in Table 1-1.
Table 1-1 GS driver model (rated voltage: 400v)
Driver model
BKSC-41P5GS□ 2.5 4 3 1.5 Yes
BKSC-42P2GS□ 3 6 5 2.2 Yes
BKSC-43P7GS□ 5.5 9 8 3.7 Yes
BKSC-45P5GS□ 8.5 14.2 13 5.5 Yes
Rated
capacity(KVA)
Rated input
current (A)
Rated output
current (A)
Adapt motor
power (kW)
Built-in
brake unit
BKSC-47P5GS□ 11 18 17 7.5 Yes
BKSC-4011GS□ 17 26 25 11 Yes
BKSC-4015GS□ 21 35 32 15 Yes
BKSC-4018GS□ 24 38.5 37 18.5 Yes
BKSC-4022GS□ 30 46.5 45 22 Yes
BKSC-4030GS□ 40 62 60 30 Yes
Page 14
GS DRIVER CTB
BKSC-4037GS□ 50 76 75 37 Yes
BKSC-4045GS□ 60 92 90 45 Yes
BKSC-4055GS□ 72 113 110 55 Yes
BKSC-4075GS□ 100 157 152 75 Yes
BKSC-4090GS□ 116 190 185 90 No
BKSC-4110GS□ 138 236 230 110 No
BKSC-4132GS□ 167 288 280 132 No
BKSC-4160GS□ 200 345 336 160 No
Unpacking inspection
Please confirm the following items when you get the product. Please contact directly with
the dealer or manufacturer that purchased from for any adverse situation. Please see Table
1-2 for detail.
Table 1-2 Confirm items
Confirm item Confirm method
Confirm that the materials listed on
the packing list are complete.
Are they in line with the ordered
Check the materials in the packing against the
packing list stuck to the external packing.
Please confirm the label at the side of the driver.
merchandise?
Is there any damage? Check the overall appearance for damage during
transportation.
Page 15
GS DRIVER CTB
Standard specifications and performance parameters
Please see Table 1-3 for standard specifications and performance parameters of 3-phase Class 400V driver
Table 1-3 Standard specifications and performance parameters of GS □ driver
Model BKSC-××××GS□ 41P5 42P2 43P4 45P5 47P5 4011 4015 4018 4022 4030 4037 4045 4055 4075 4090 4110 4132 4160 4185 4220 4315
Adapt motor power kW 1.5 2.2 3.7 5.5 7.5 11 15 18.5 22 30 37 45 55 75 90 110 132 160 185 220 315
Capacity KVA
Output
Current A
Maximum output voltage V
Maximum output speed rpm
Power
Rated voltage and frequency
Allowed voltage pulsation
Control mode Sine wave PWM modulation, entirely closed-loop vector control
Torque feather
Control characteristics
Range of speed regulation 1: 5000
Speed control accuracy ±0.1%
Frequency set resolution
Position control accuracy ±1PULSE
Acceleration
2.5 3 5.5 8.5 11 17 21 24 30 40 50 60 72 100 116 138 167 200 280 340 460
3 5 8 13 17 25 32 37 45 60 75 90 110 152 185 230 280 336 370 450 630
3-phase 380/400/415/440V corresponding input voltage
4-pole motor 15000rpm: 500Hz
3-phase 380/400/415/440V: 50/60Hz±5%
+10%, -15%
200% rated torque output below the fundamental frequency. Accuracy: ±5%
Digital quantity: : 0.01Hz; analog quantity: Unipolar, maximum output frequency is /4092; bipolar, maximum output
frequency is / 2046
0.05~3000Hz/s
Brake mode
Overload capacity 200% rated current 30s
dynamic braking. 125% rated torque: built-in braking unit (external braking resistor)
Page 16
GS DRIVER CTB
Digital quantity input 7-channel isolation photo-coupler input; input mode: PNP, NPN optional
Digital quantity output 2-channel isolation photo-coupler output; 24V, 10mA
Input output interface
Analog quantity input
Analog quantity output None
Relay output 1 channel N.O. type; AC250V/DC30V, 1A
Fault output relay 1 channel: a group of N.O/N.C contact; AC250V/DC30V, 1A
Encoder input interface One: maximum receive frequency is 300KHz; cable driven receive mode: RS422 standard
PULSE input interface One: direction PULSE or orthotropic PULSE
Encoder output interface One: maximum output frequency is 300KHz; cable driven output mode: RS422 standard
3-channel; -10V~+10V 1 channel, 0~10V 2-channel
function
Spindle
Protection
function
environment
Service
Bus interface
Speed control
Accurate stop Accuracy: ±1PULSE; position adjustment: set by user's parameter
Rigid tapping
Other function C-axis control, thread cutting, electronic gear, reaming, swing control
Spindle motor over-current Greater than 200% rated current output
Motor overload Specified time of exceeding overload alarm value. Alarm output: set by parameters
Overvoltage The voltage of main circuit bus is higher than 800V. Alarm output
Low voltage The voltage of main circuit bus is lower than 400V. Alarm output
Service site Free of dust, corrosive gas and inflammable gas
Temperature
Humidity
Vibration
RS232,can,Ethernet network
Range: 0~15000rpm; turning: positive and negative; speed order: analog quantity, imPULSE frequency and bus
May be connected to several domestic and foreign system. Tapping error: ±2%
-10~45℃
Lower than 95%RH (no condensation)
2
vibration frequency≤20Hz: 9.8m/s
;20Hz≤vibration frequency≤50Hz: 2m/s2;
Page 17
GS DRIVER CTB
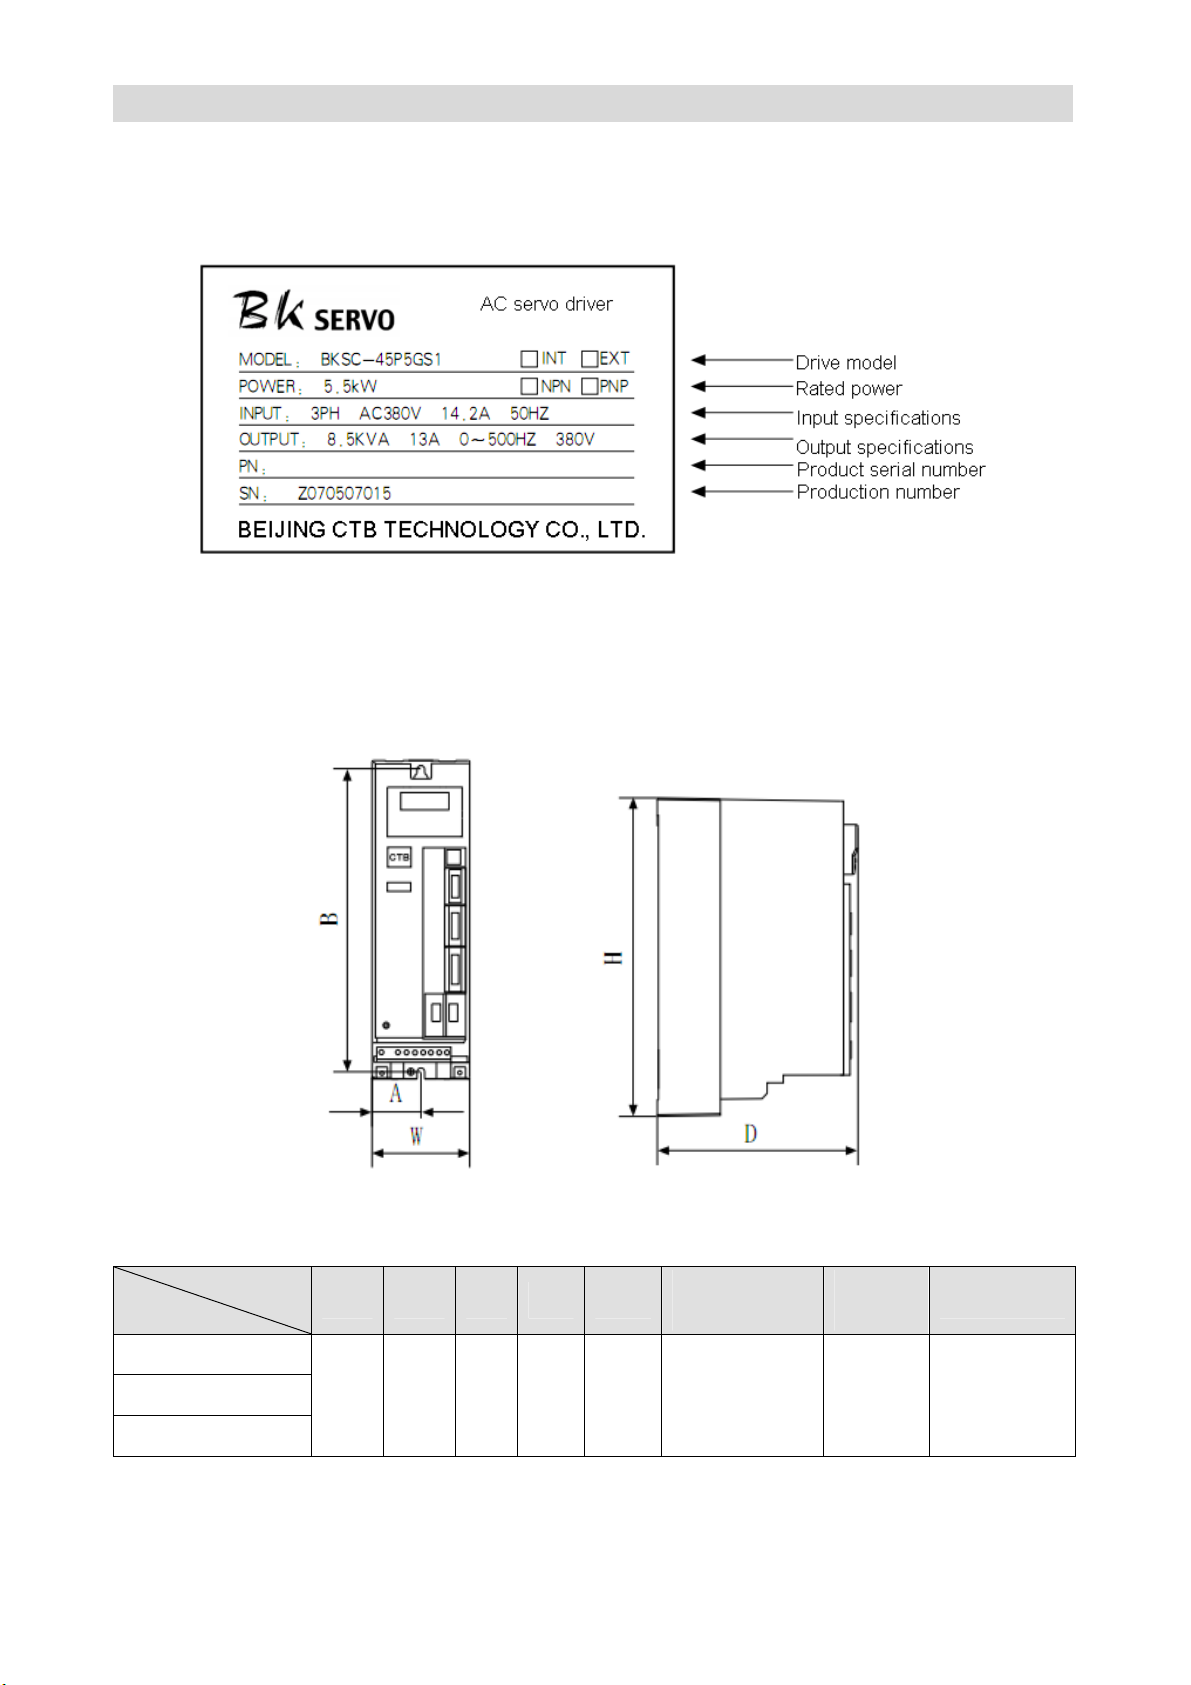
Driver nameplate description
Nameplate which indicates model and rated values of the driver is affixed to the lower right
of housing of the driver. The content of the nameplate is shown in Figure 1-1.
Figure 1-1 Servo driver nameplate
External dimensions and installation dimensions
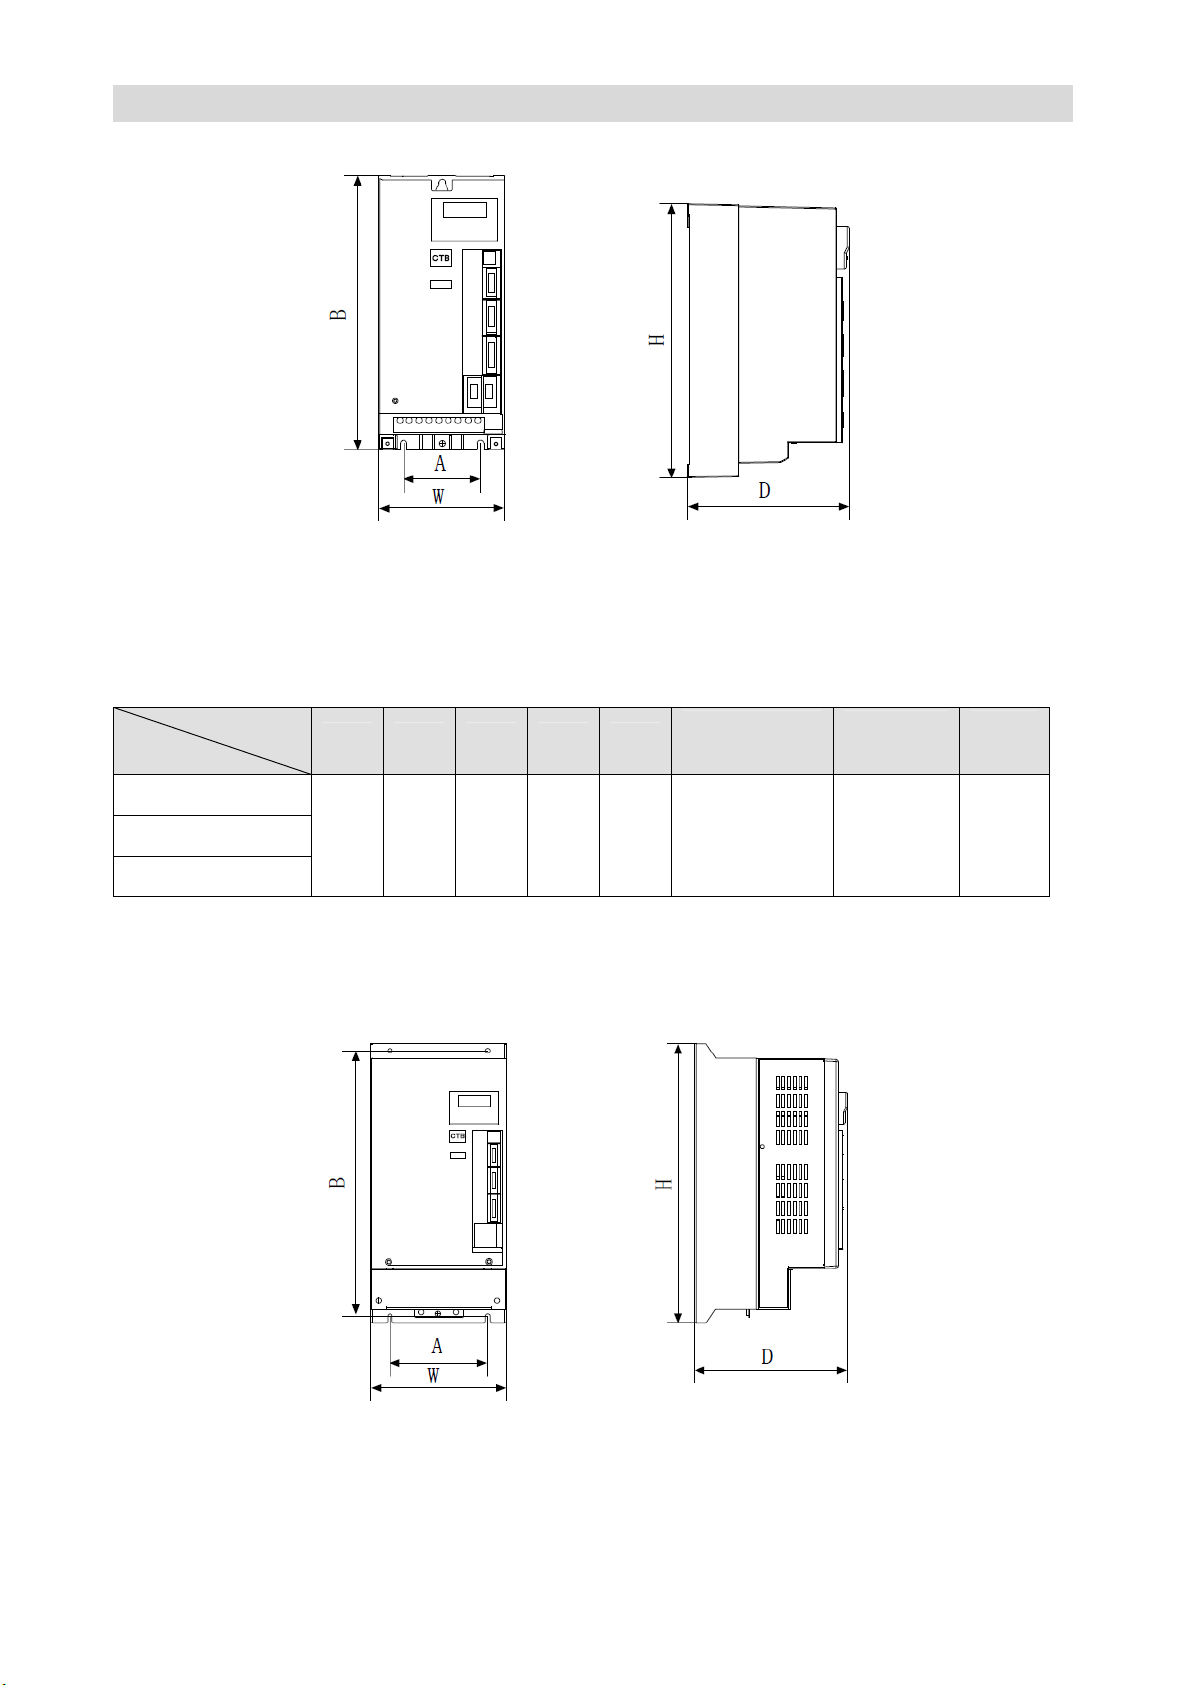
1. 1.5-3.7kw driver
Please see diagram 1-2 for external dimensions and installation dimensions
Figure 1-2
Table 1-4 Dimensions (mm) and weight (kg) of GS DRIVER (1.5-3.7kw) driver
Model
Dimension
A B W H D
Connecting
terminal screw
Installati
on screw
Weight (kg)
BKSC-41P5GS□
BKSC--42P2GS□
BKSC--43P7GS□
2. 5.5~11kw driver
45.5 276 91 290 200
Wire nail width
3mm
M6 3
Page 18
GS DRIVER CTB
Please see diagram 1-3 for external dimensions and installation dimensions
Figure 1-3
Table 1-5 Dimensions (mm) and weight (kg) of GS DRIVER (5.5-11kw) driver
Dimension
Model
BKSC--45P5GS□
BKSC--47P5GS□
BKSC--4011GS□
A B W H D
80 276 132 290 200
Connecting
terminal screw
Wire nail width
3mm
Installation
screw
M6 5
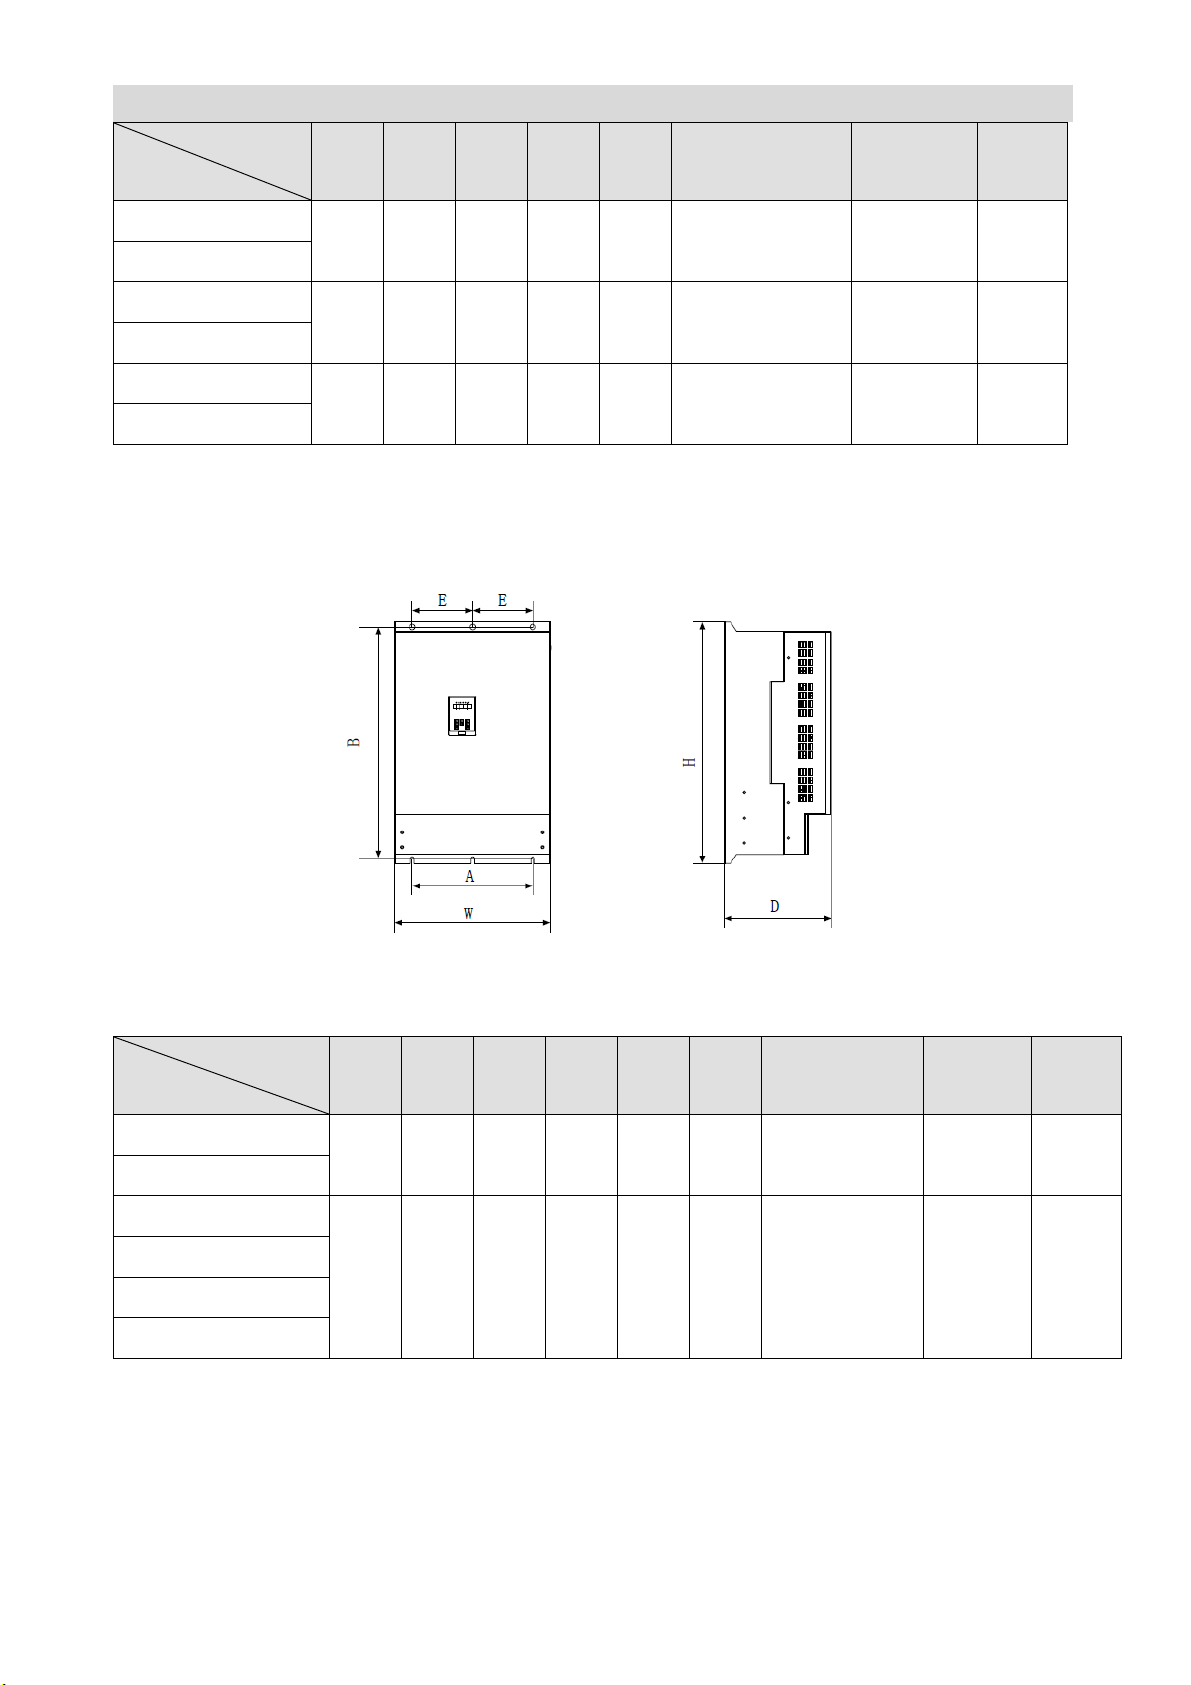
3. 15~45kw driver
Please see diagram 1-4 for external dimensions and installation dimensions.
Weight
(kg)
Figure 1-4
Table 1-6 Dimensions (mm) and weight (kg) of GS DRIVER (15-45kw) driver
Page 19
GS DRIVER CTB
Dimension
Model
BKSC--4015GS□
BKSC--4018GS□
BKSC--4022GS□
BKSC--4030GS□
BKSC--4037GS□
BKSC--4045GS□
A B W H D
140 376 194 390 228 M6 M6 14
236 376 282 390 228 M6 M8 20
300 376 380 390 269 M8 M8 26
Connecting
terminal screw
Installation
screw
Weight
(kg)
4. 55~160kw driver
Please see diagram 1-5 for external dimensions and installation dimensions
Figure 1-5
Table 1-7 Dimensions (mm) and weight (kg) of GS DRIVER (55-160kw) driver
Dimension
Model
BKSC--4055GS□
BKSC--4075GS□
BKSC--4090GS□
BKSC--4110GS□
BKSC--4132GS□
BKSC--4160GS□
A B W H D E
392 376 472 390 269 196 M10 M8 33
360 690 464 720 320 180 M10 M16
Connecting
terminal screw
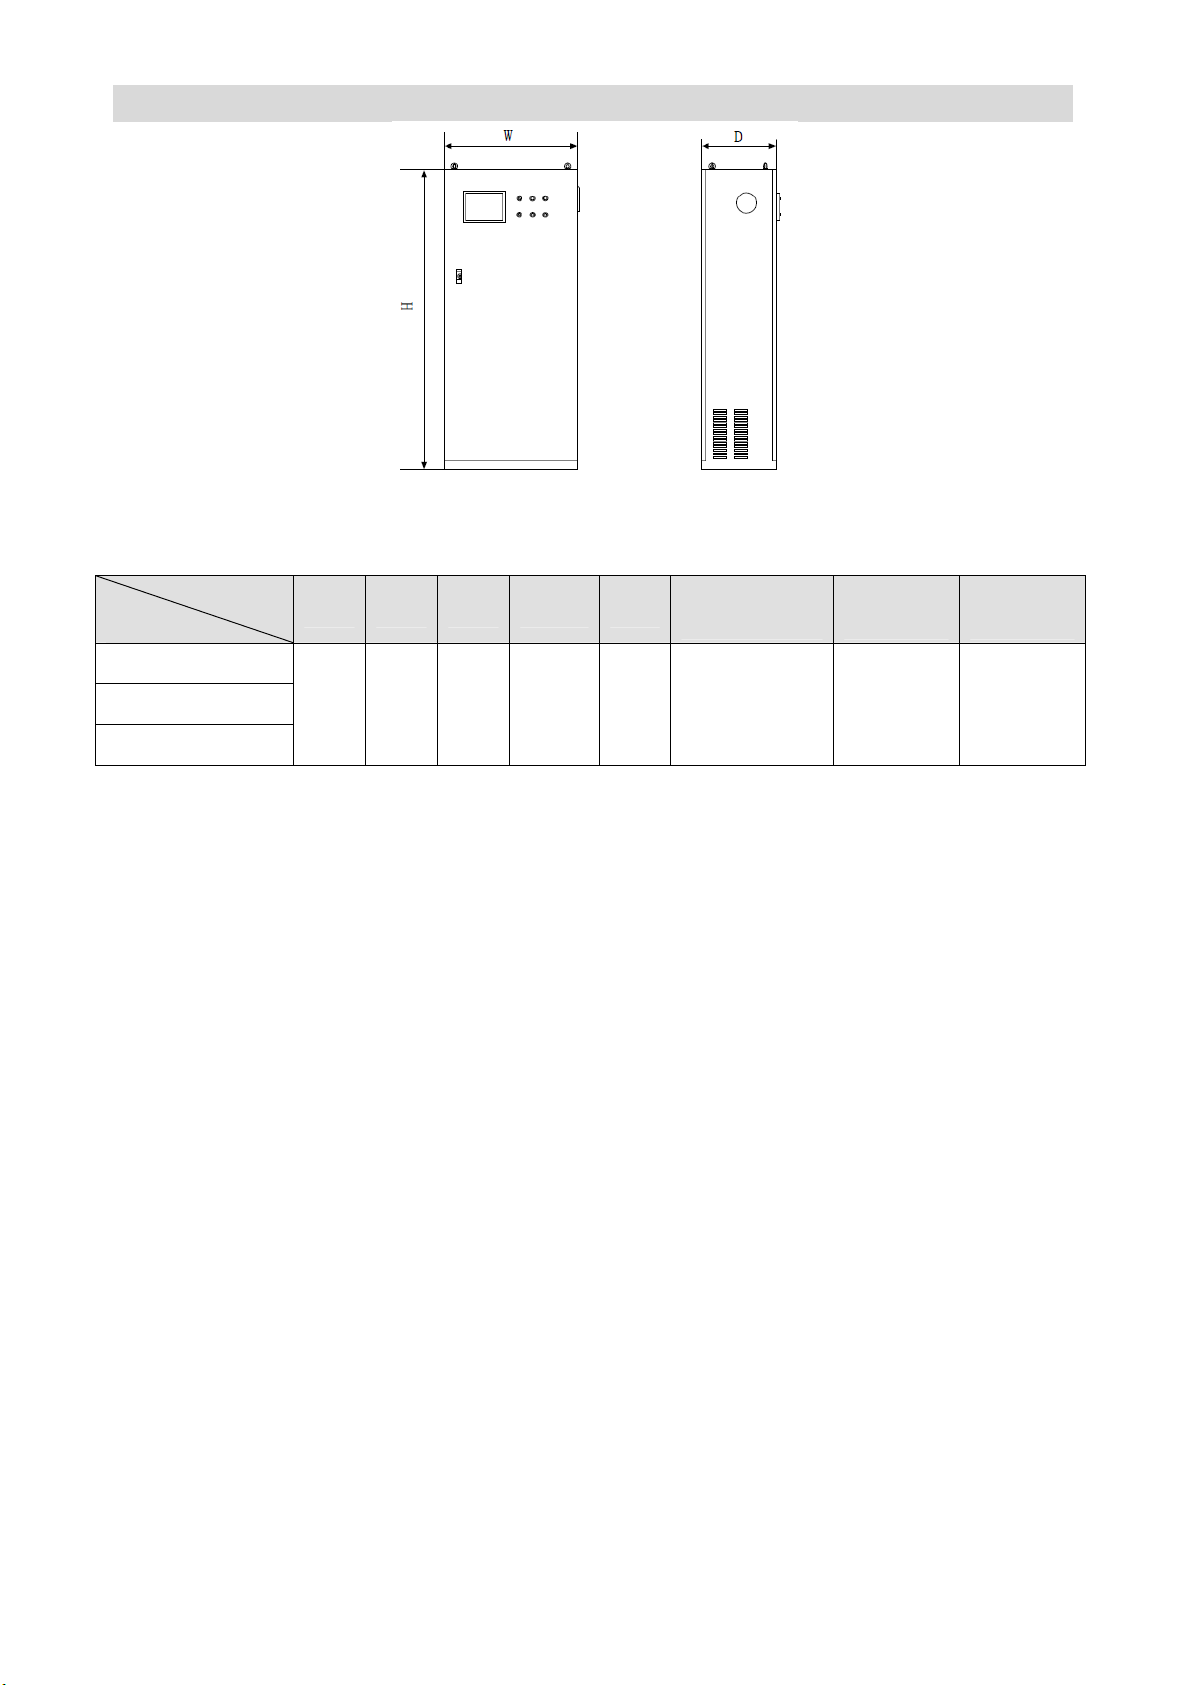
5.185 ~ 315kw driver
Please see diagram 1-6 for external dimensions and installation dimensions
Installati
on screw
Weight
(kg)
90
Page 20
GS DRIVER CTB
Figure 1-6
Table 1-8 Dimensions (mm) and weight (kg) of GS DRIVER (185-315kw) driver
Dimension
Model
BKSC -4185GS□
BKSC -4220GS□
BKSC -4315GS□
A B W H D
- - 800 1800 450 - - 230
Connecting
terminal screw
Installation
screw
Weight
(kg)
Confirmation and requirements of the installation space
Installation environment
The following items shall be noted when selecting the installation environment:
1. Ambient temperature: operate in -10℃ ~ 45℃; if the ambient temperature is higher than
45℃, the equipment shall be used with 30% derating for each 5℃ temperature rise.
★ Note: If the ambient temperature is higher than 45 ℃ , the ventilation shall be
strengthened, and use by the specified derating.
2. The humidity of the installation site shall lower than 95%, and free of condensing;
3. Do not install the equipment in place with dust or metal powder;
4. The equipment shall be installed at place without corrosive, explosive gas;
5. The equipment shall be installed at place that meet the requirements of vibration. The
vibration frequency ≤ 20Hz: 9.8m/s2; 20Hz ≤ vibration frequency ≤ 50Hz: 2m/s2;
6. The equipment shall be installed at place away from direct sunlight.
Installation direction and space
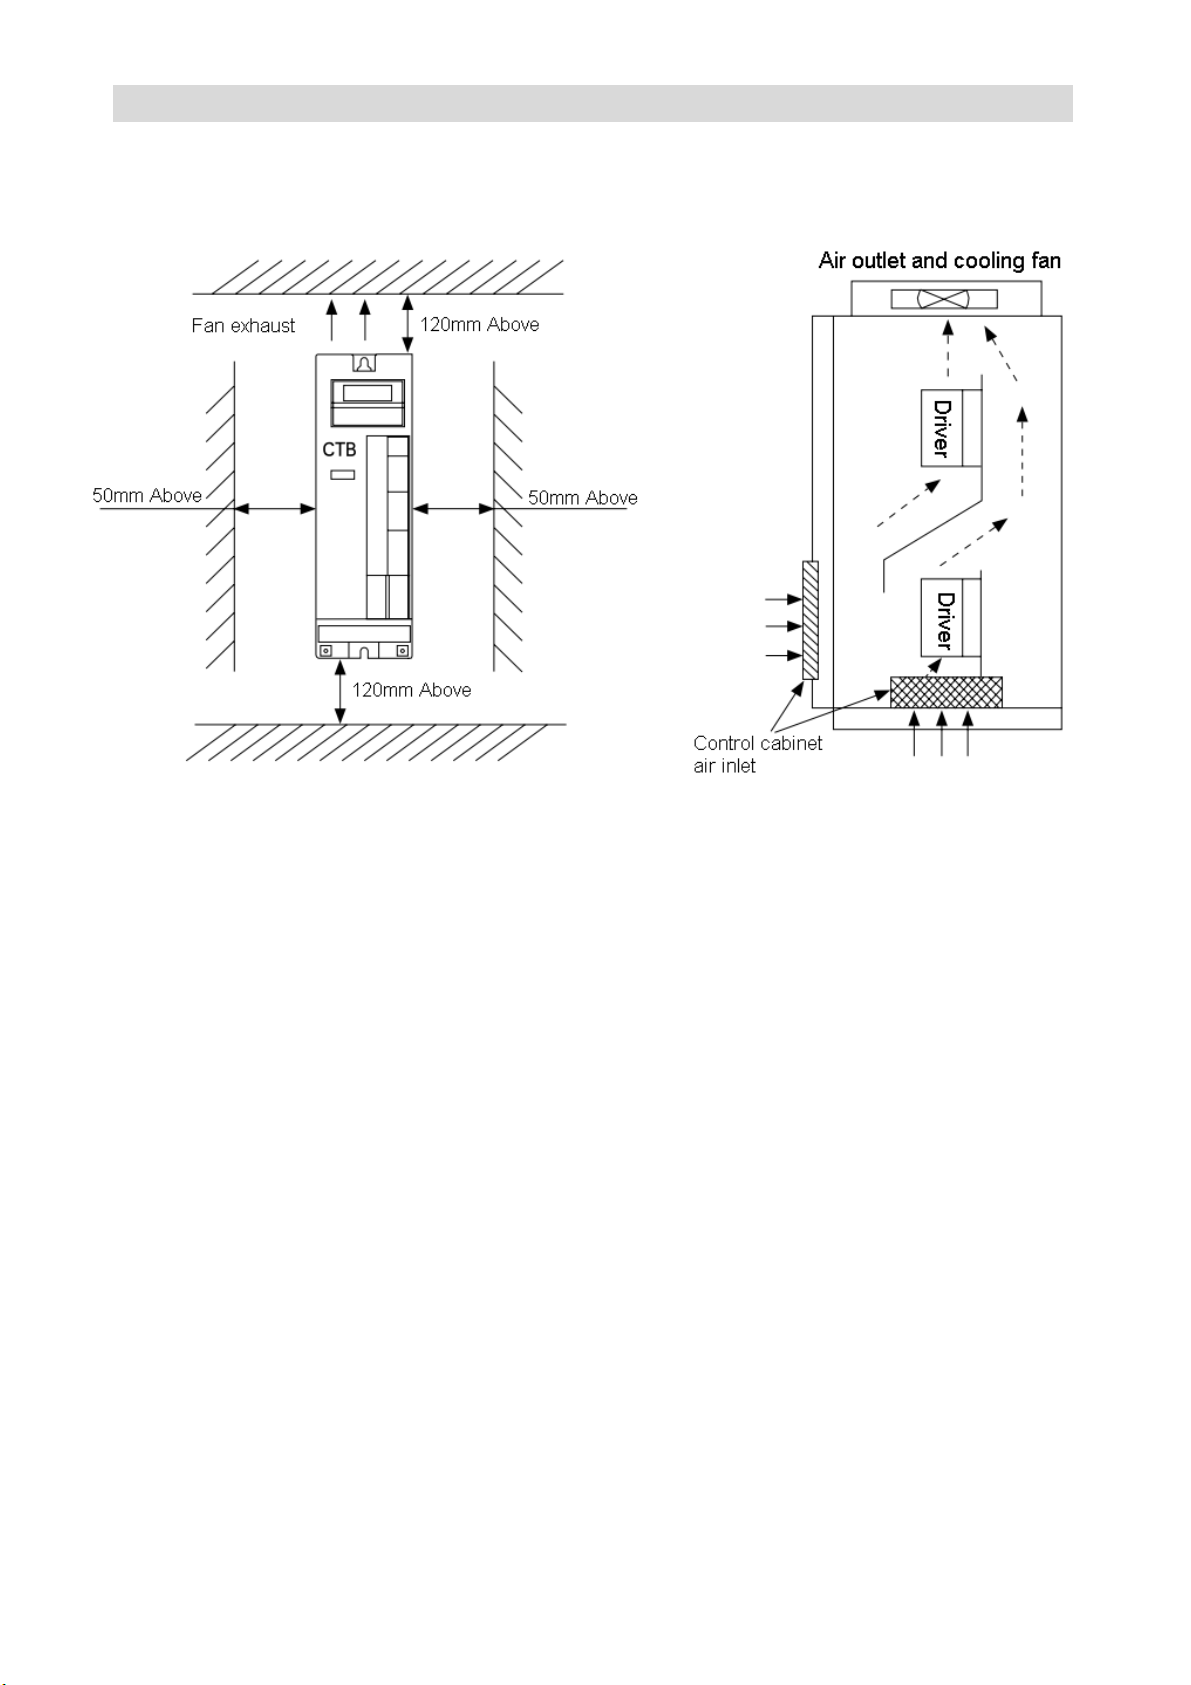
●Installation spacing and distance requirements of single driver are shown in Figure 1-7.
● Generally, abreast installation mode is adopted when multiple drivers are installed in the
Page 21
GS DRIVER CTB
control cabinet, and air inlet, outlet and dedicated cooling fan shall be equipped; if up and
down installation mode is adopted, stream guidance clapboard shall be added between
drivers to guarantee good cooling effect as shown in Figure 1-8.
Figure 1-7 Single controller installation Figure 1-8 Multiple controllers installation
Notes on motor and load
Compared with frequency conversion operation
GS DRIVER is full closed-loop vector servo driver. It adjusts output voltage and current
automatically according to the load change. It's more energy-efficient than inverter with
higher speed control accuracy and wider speed regulation range. As the controlled motor
and driver are closed loop, the control of position, speed and torque can be achieved
conveniently.
Constant torque operation
When motor works in constant torque area, the output torque of the motor is required by the
mechanical operation instead of the rated torque of the motor. However, the maximum
continuous output torque of the motor must not exceed the rated torque.
High-speed operation in constant power area
For high-speed operation in constant power area, the increased vibration and noise shall
be considered, and the service speed range of motor bearing and mechanical devices must
be confirmed, and consulted in advance. It's strictly prohibited to make the machine operate
above the rated speed.
Page 22
GS DRIVER CTB
Lubrication of the mechanical device
For reduction box and gear head motor and other mechanical device that requires
lubrication, damage may be caused due to deterioration of lubricating effect in long-term
low-speed operation. It must be consulted in advance.
Negative torque load
Negative torque load occurs frequently for load such as lifting. The driver will generate
over-current and overvoltage alarm and trip. Equipping of brake components or mechanical
safety devices shall be considered.
Reciprocating load
Please pay attention to unstable phenomenon in output current when the driver is driving
piston reciprocating load. The phenomenon is more prominent in long-term low-frequency
operation. The capacity of driver shall be increased.
Mechanical resonance point of the load device
The driver may encounter the mechanical resonance point of the load device in certain
output frequency range. It can be avoided by setting jump frequency.
Notes on the driver
Applications not in rated voltage
The servo driver shall not be used in voltage that not in the working voltage range. Please
conduct voltage transformation with appropriate step-up or step-down unit as required.
Note on the drive phase input into 2-phase input
The device shall not be changed into 2-phase input, otherwise, default phase protection will
occur.
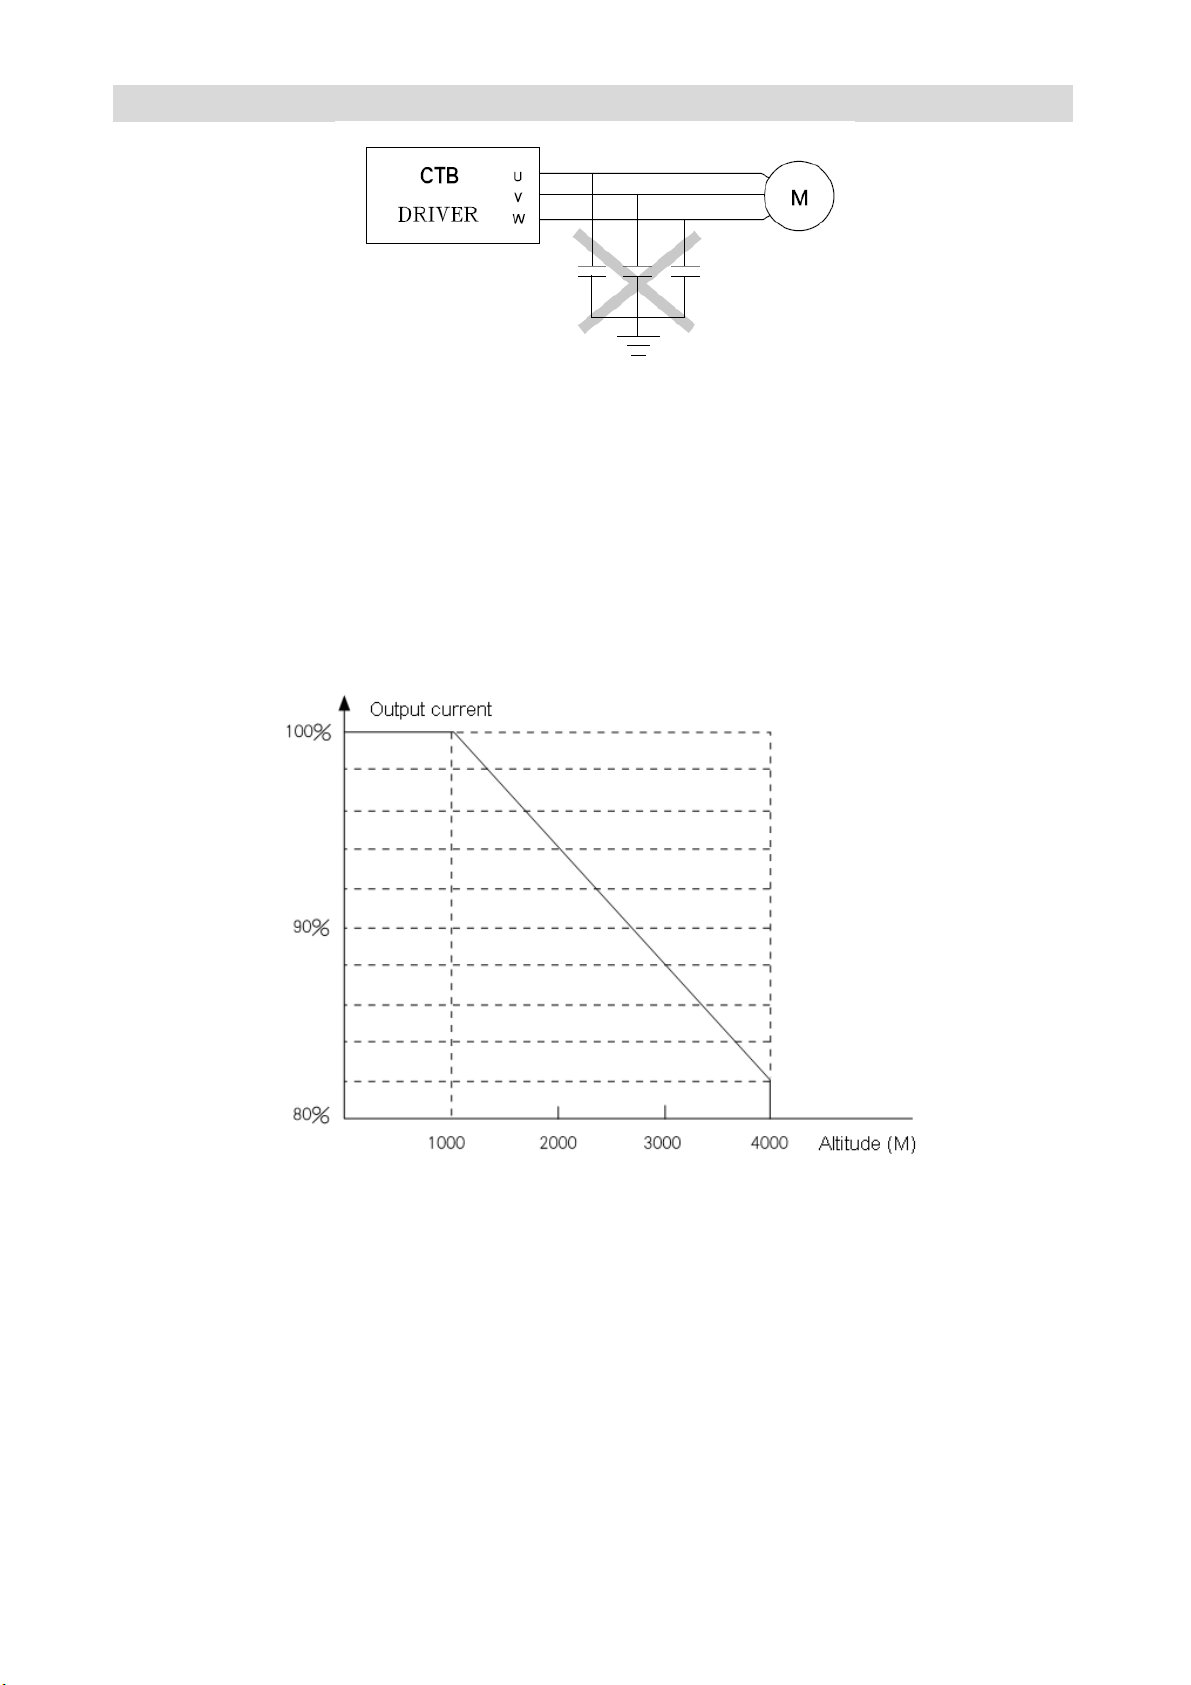
Capacitor or pressure-sensitive device to improve power factor
As shown in Figure 1-9, the output of the driver is PULSE wave, drive failure tripping or
damage to the device will be caused due to capacitor or pressure-sensitive device for
lightning to improve power factor installed at the output side. They must be removed.
Page 23
GS DRIVER CTB
Figure 1-9 Capacitor is prohibited at the output end of controller
Lightning attack protection
lightning over-current device is equipped in the driver for self-protection to induction stroke
Altitude and derating operation
For areas with altitude over 1000 m, derating operation is necessary due to deterioration of
cooling effect of the drive caused by thin air. The relationship curve of rated current of driver
and altitude is shown in Figure 1-10.
Figure 1-10 Derating curve of rated current of driver and altitude
Notes on scrapping:
Explosion of electrolytic capacitor: the electrolytic capacitors on main circuit and printed
panel may explode when incinerated.
Plastic incineration waste gas: toxic gases will be generated in incineration of front panel
and other plastic parts.
Processing method: please process the waste as industrial waste.
★ Description: The contents of the manual are subject to change due to product upgrade
or optimize. The new version shall prevail.
Page 24
GS DRIVER CTB
Wiring
The chapter describes the wiring specifications of power supply terminals and control circuit
terminals, and install wiring specifications of control board jumpers and expansion interface
board.
Selection and connection of peripheral devices………………………..2-2
Wiring of the main circuit terminals………………………………………2-3
Wiring of control circuit ………………………………………………….2-10
Connection of the encoder interface…………………………………..2-15
Connection of the serial communication port ………………………..2-16
Page 25
GS DRIVER CTB
Selection and connection of peripheral devices
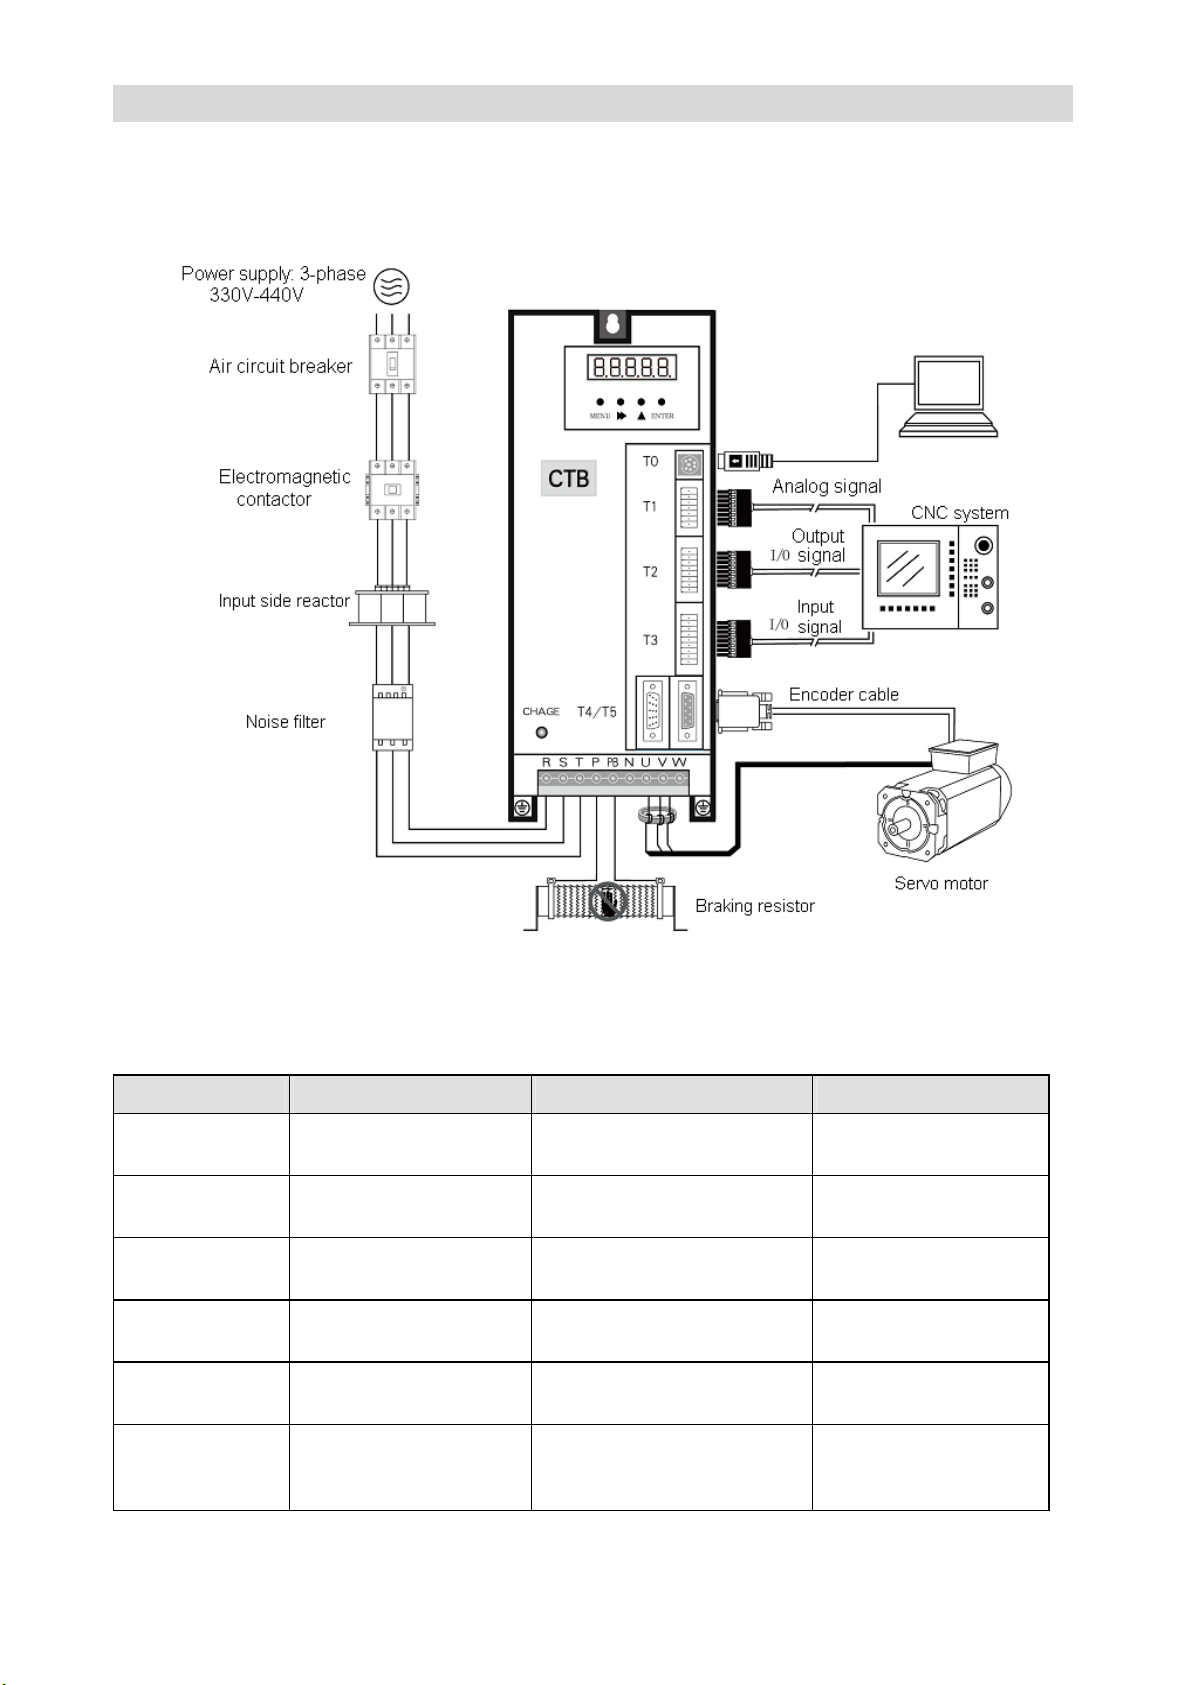
Spindle driver and peripheral devices connection diagram, take 15kw drives as an example
in Figure 2-1.
Figure 2-1 Spindle driver and peripheral devices connection diagram
Parts selection description
Item Usage Selection note Remarks
Air circuit breaker
Electromagnetic
contactor
Input side reactor
Input noise filter
Braking resistor
Filtering magnet
ring
Turn on or off driver
power
For automatic power on
of driver
Improve power factor of
power grid
Suppress interference of
driver to power supply
Consume regenerated
energy of the driver
Suppress wireless
interference of the driver
to outside
Select by 150% of rated
current of the driver
Select by 150% of rated
current of the driver
Select by 100% of rated
current of the driver
Select by 150% of rated
current of the driver
Select by standard provided
by the factory
Select by standard provided
by the factory
Refer to Table 2 - 3
Refer to Table 2 - 3
Refer to Table 2 - 2
Refer to GS model
selection sample
Page 26
GS DRIVER CTB
Wiring of the main circuit terminals
The structure of the main circuit
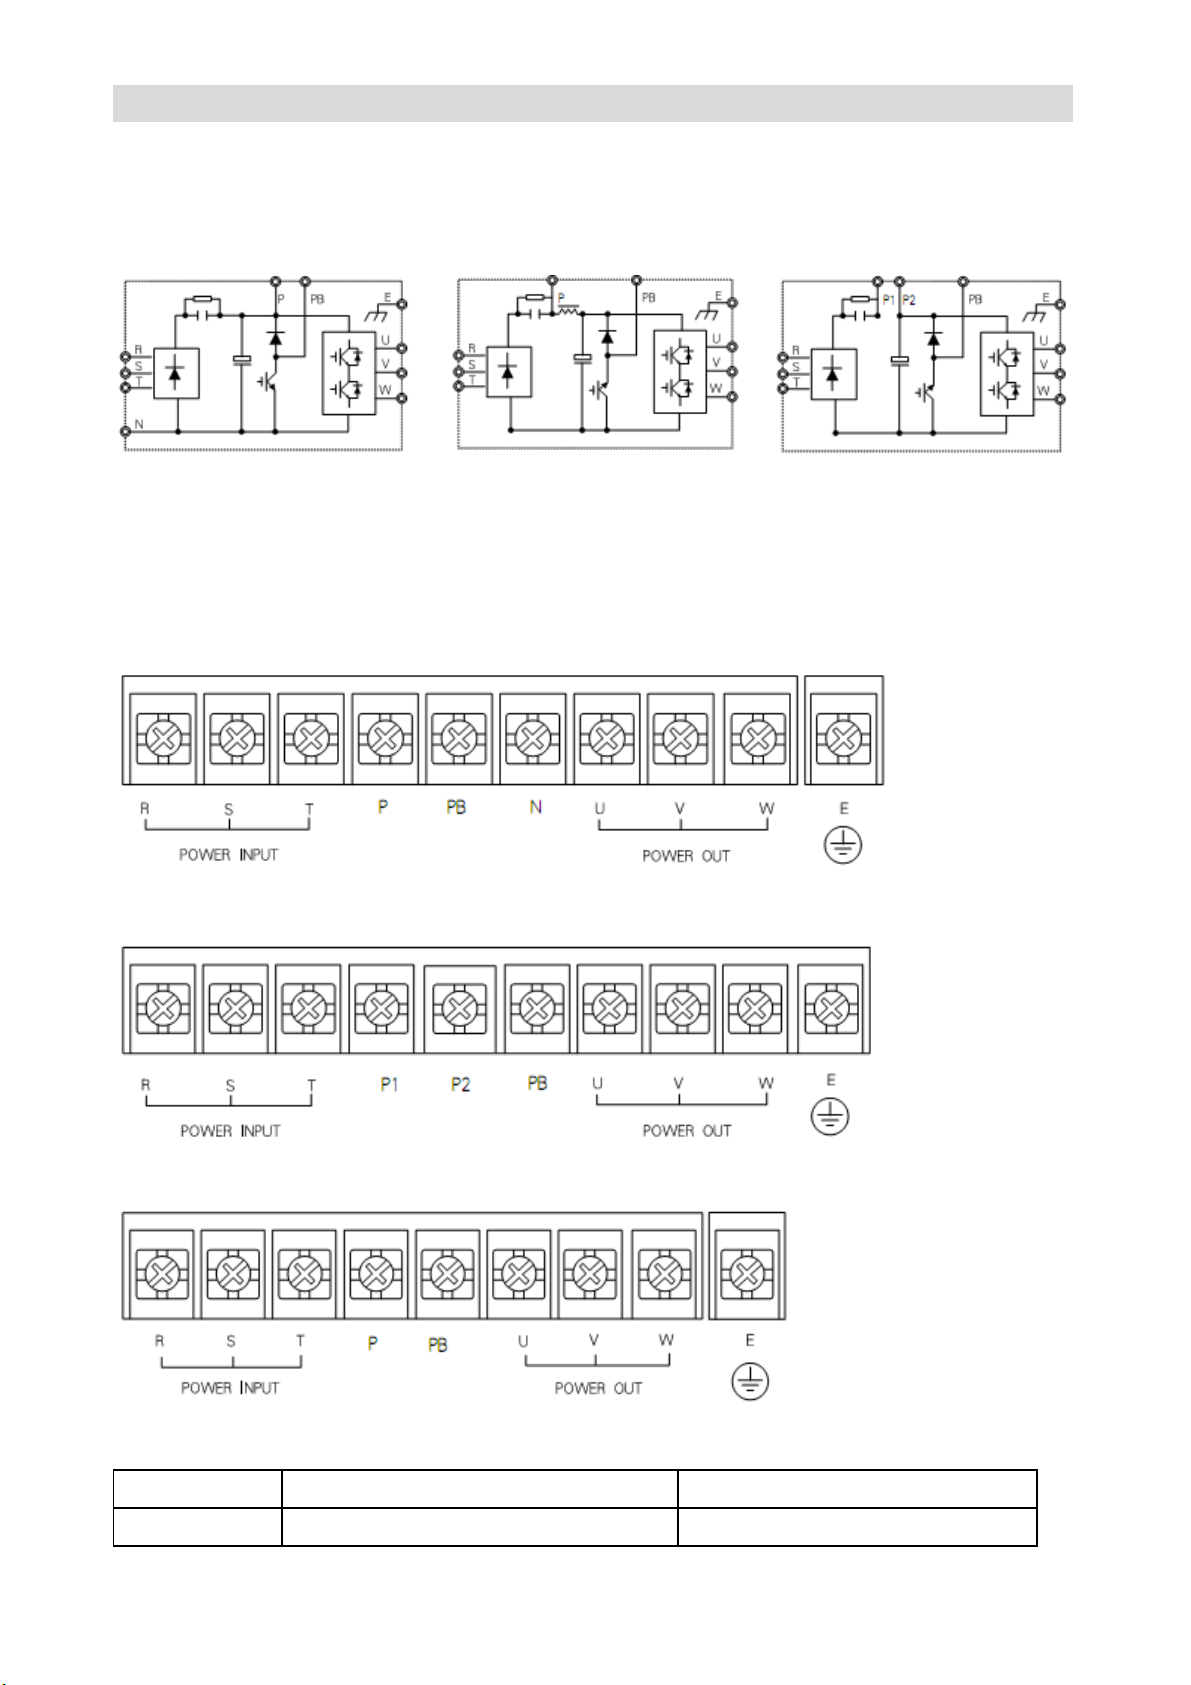
See Figure 2-2A, 2-2B and 2-2C for internal structure diagram of the main circuit.
Figure 2-2A 1.5~15kw main
circuit composition
Figure 2-2B 18.5~75kw main
circuit composition
Main circuit terminals composition
1.5~22kw main circuit terminals composition
37~75kw main circuit terminals composition
Figure 2-2C 90~160kw main
circuit composition
90~160kw main circuit terminals composition
Main circuit terminals and functional description
Item Function Notes
R S T
3-phase AC supply input terminal.
Need to install breaker for protection
Page 27
GS DRIVER CTB
380~440V, 50/60Hz
P P1 DC bus positive pole
P2 DC reactor wiring terminal P1 and P2 are for external DC reactor
Pb Braking resistor wiring terminal
n DC bus negative pole
U V w Driver output terminal
E Earth terminal
P and N are for input of external
braking unit or DC power input
P, P2 and PB are for external braking
resistor
N and P are for external braking unit
or DC power input
Consistent with the phase sequence
of the motor during wiring
C type grounding, the grounding
resistance≤ 4Ω
Wiring of input side of the main circuit
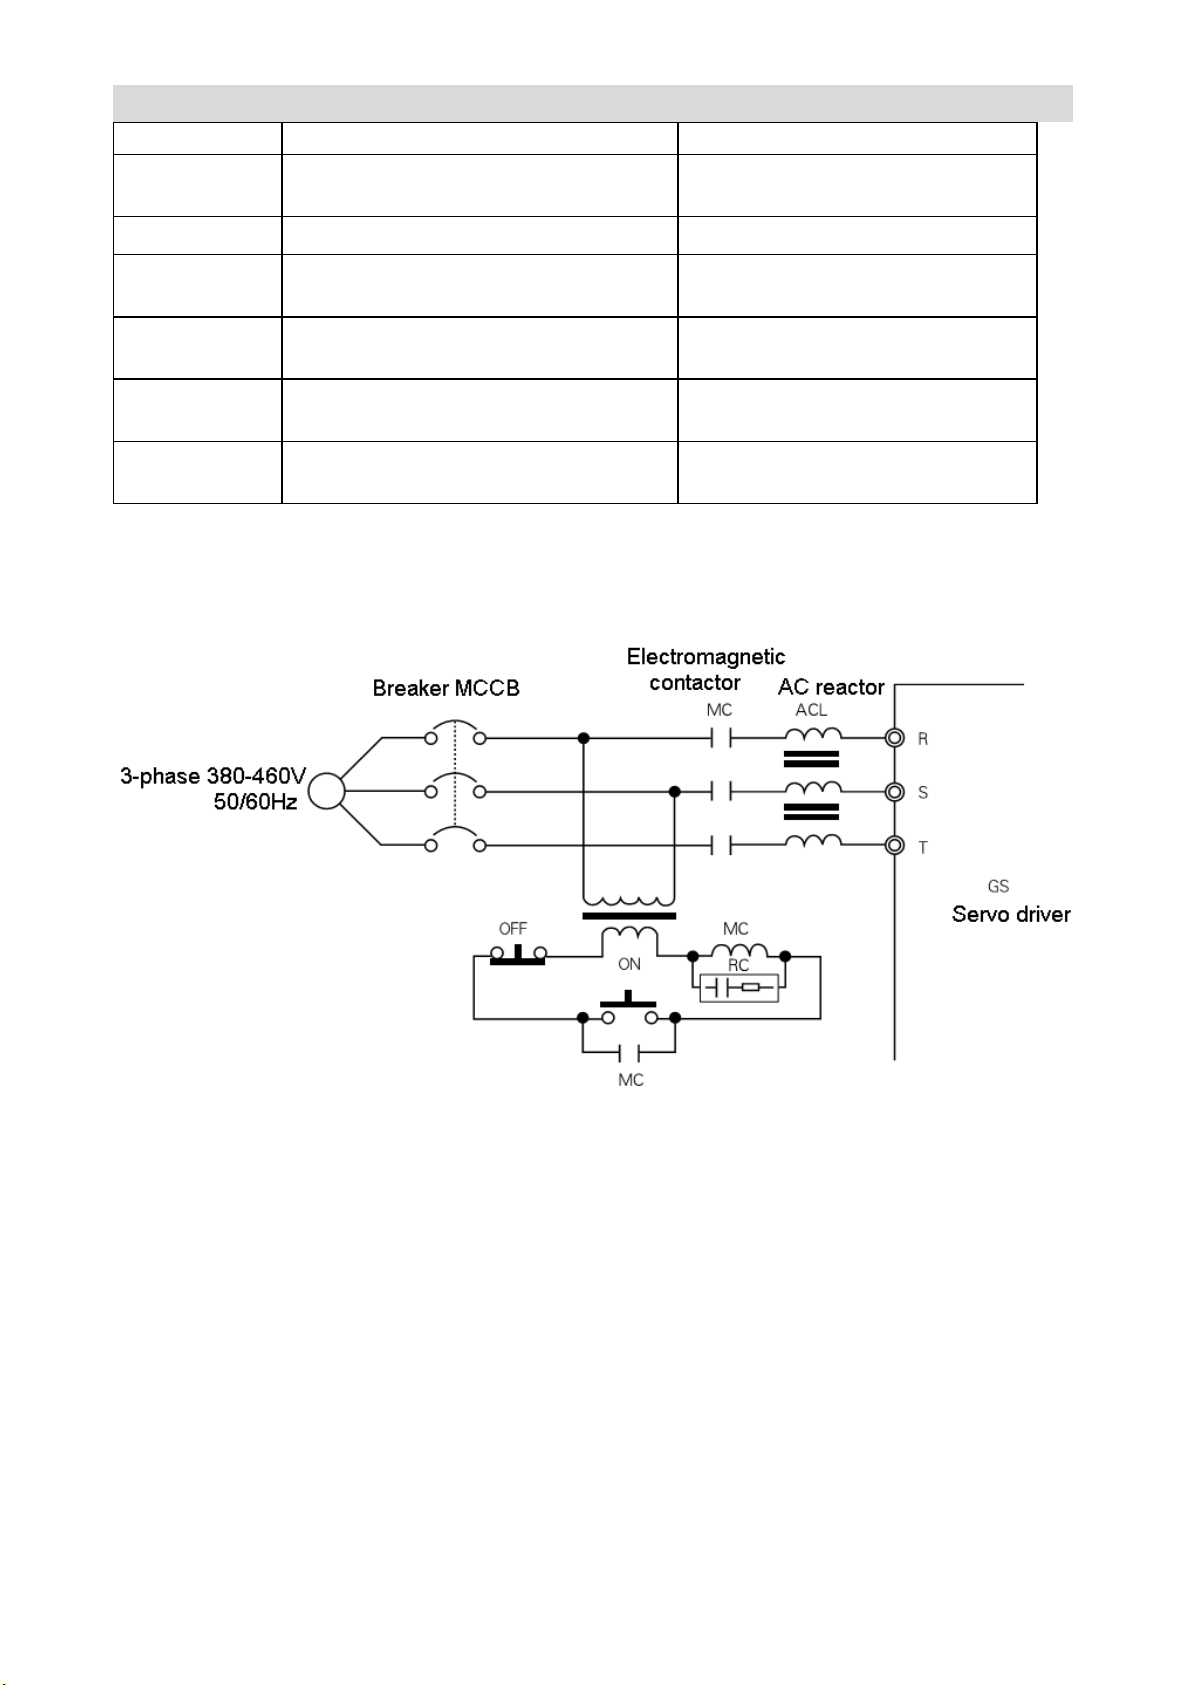
Please pay attention to the following items for wiring of input side of the main circuit. See
Figure 2-3 for standard wiring.
Incoming line circuit breaker (MCCB)
The main circuit power input terminals (R, S, T) must be connected to 3-phase AC power
through line protection circuit breaker (MCCB).
● The selection of MCCB must be in accordance with requirements in Table 2-3.
●The time characteristics of MCCB must take overload characteristics (rated output current
200%/min) and time characteristics of the servo driver into account.
●Each servo driver shall be equipped with independent breaker; when multiple drivers
share a circuit breaker, to cut off the power supply and prevent the failure expansion during
driver failure, it's recommended to control the incoming line electromagnetic contactor with
the fault output relay of the driver to ensure safety.
Page 28
GS DRIVER CTB
Installation of the residual current circuit breaker
The output of the servo driver is a high frequency PULSE wave so that there is
high-frequency leakage current generated. Residual current circuit breaker can be used at
the incoming line side of the driver to remove high-frequency leakage current, and only
inspect channel current that dangerous to human body. Please select special residual
current circuit breaker for servo (inverter) for wiring.
● When select special residual current circuit breaker, please select model for control of
one driver with an induction current over 30ma.
●When select normal residual current circuit breaker, please select model for control of one
driver with an induction current over 200ma, and a time over 0.1s.
●Installing isolation transformer between normal residual current circuit breaker and servo
driver can effectively avoid malfunction of the breaker.
Incoming line electromagnetic contactor
Incoming line electromagnetic contactor may be used to cut off the power in sequential
control. It cannot be used as start of servo driver. When cut off power of servo driver
compulsorily with incoming line electromagnetic contactor, servo driver is in power-off
alarm state, motor only can slide freely and stop.
● Frequent turning on/off incoming line magnetic contactor may cause heating, even
burning of charging resistor of the driver (driver interior).
● The time interval of turning on/off incoming line magnetic contactor shall be longer than
10 minutes.
AC reactor
Installing AC reactor at the incoming line side of the servo driver can effectively suppress
the surge of power, avoid burning of rectification part of the driver, and also can improve the
power factor of the power supply side. Please see Figure 2-3 for connection of AC reactor,
see Table 2-1 for selection of AC reactor.
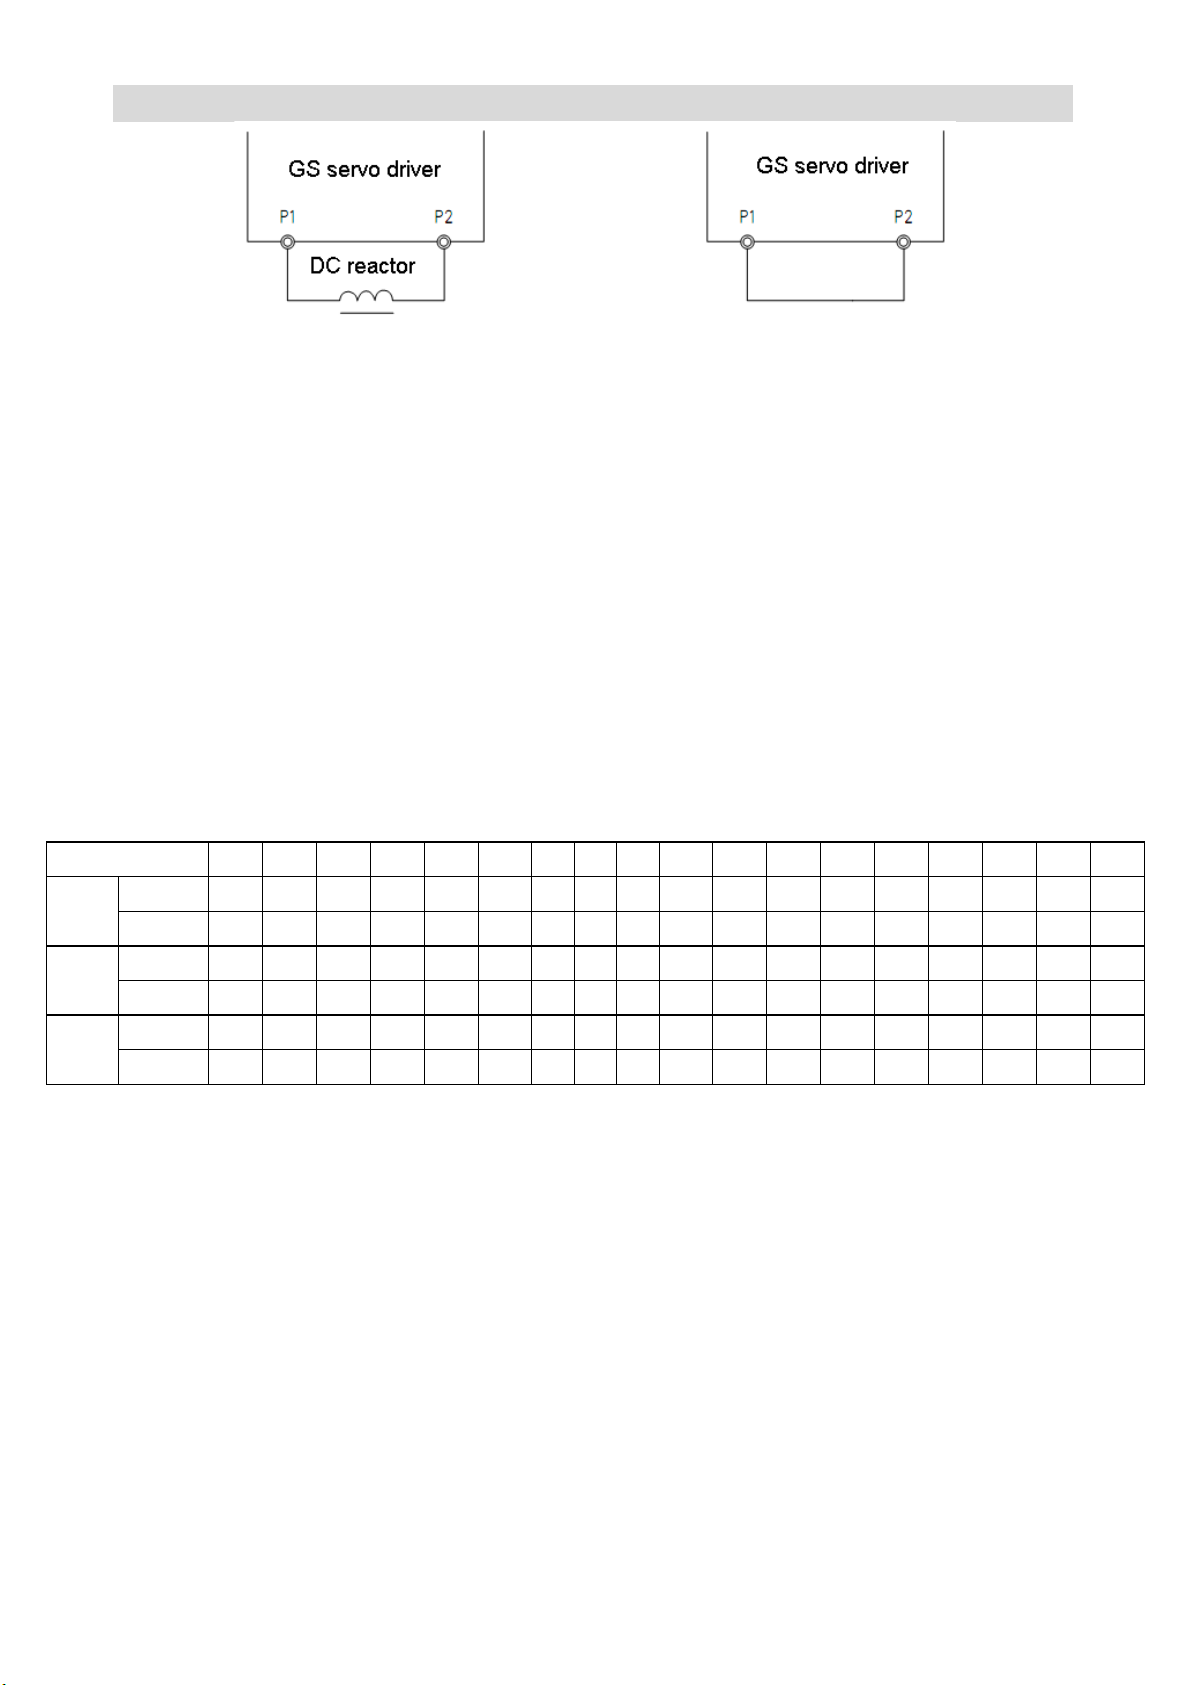
DC reactor
External DC reactor can be connected to GS servo driver above 22KW. It can effectively
suppress the surge of power, avoid burning of rectification part of the driver, and also can
improve the power factor of the power supply side. Please see Figure 2-4 for connection of
DC reactor.
External DC reactor shall not be connected to GS servo driver lower than 15 KW. For GS
servo driver above 22KW without external DC reactor shall have P1, P2 or D C + terminals
shorted as shown in Figure 2-5.
Page 29
GS DRIVER CTB
L
Figure 2-4 DC reactor connection diagram Figure 2-5 Connection diagram without DC reactor
Precautions for wiring of DC reactor
1. Please do not connect DC reactor to any main circuit terminal except P1, P2, otherwise,
it may cause internal short circuit of the driver, and burn the driver.
2. Please see Table 2-3 for specifications of DC driver connecting cable, the standard of
the main circuit cable.
3. Please see Table 2-1 for selection standard of DC reactor.
4. With external DC reactor, the P2 terminal shall be multiplex terminal, and one end of
braking resistor also shall be connected to the terminal.
Table 2-1 Selection of AC reactor, DC reactor and input filter
Driver model 41P5 42P2 43P7 45P5 47P5 4011 4015 4018 4022 4030 4037 4045 4055 4075 4090 4110 4132 4160
Current (A) 5 7 10 15 20 30 40 50 60 80 90 120 150 200 230 250 290 330
AC
reactor
reactor
Model ACL 0005 0007 0010 0015 0020 0030 00400050 0060 0080 0090 0120 0150 0200 0230 0250 0290 0490
Current (A) 15 20 25 30 35 40 50 60 70 80 90 110 150 180 200 250 270 360
DC
Model DC
Current (A) 6 6 6 10 16 25 30 50 50 65 80 100 120 150 200 250 250 320
Input
filter
Model EMI 06 06 06 010 016 025 030 050 050 065 080 0100 0120 0150 0200 0250 0250 0320
015 020 025 030 035 040 050 060 070 080 090 0110 0150 0180 0200 0250 0270 0360
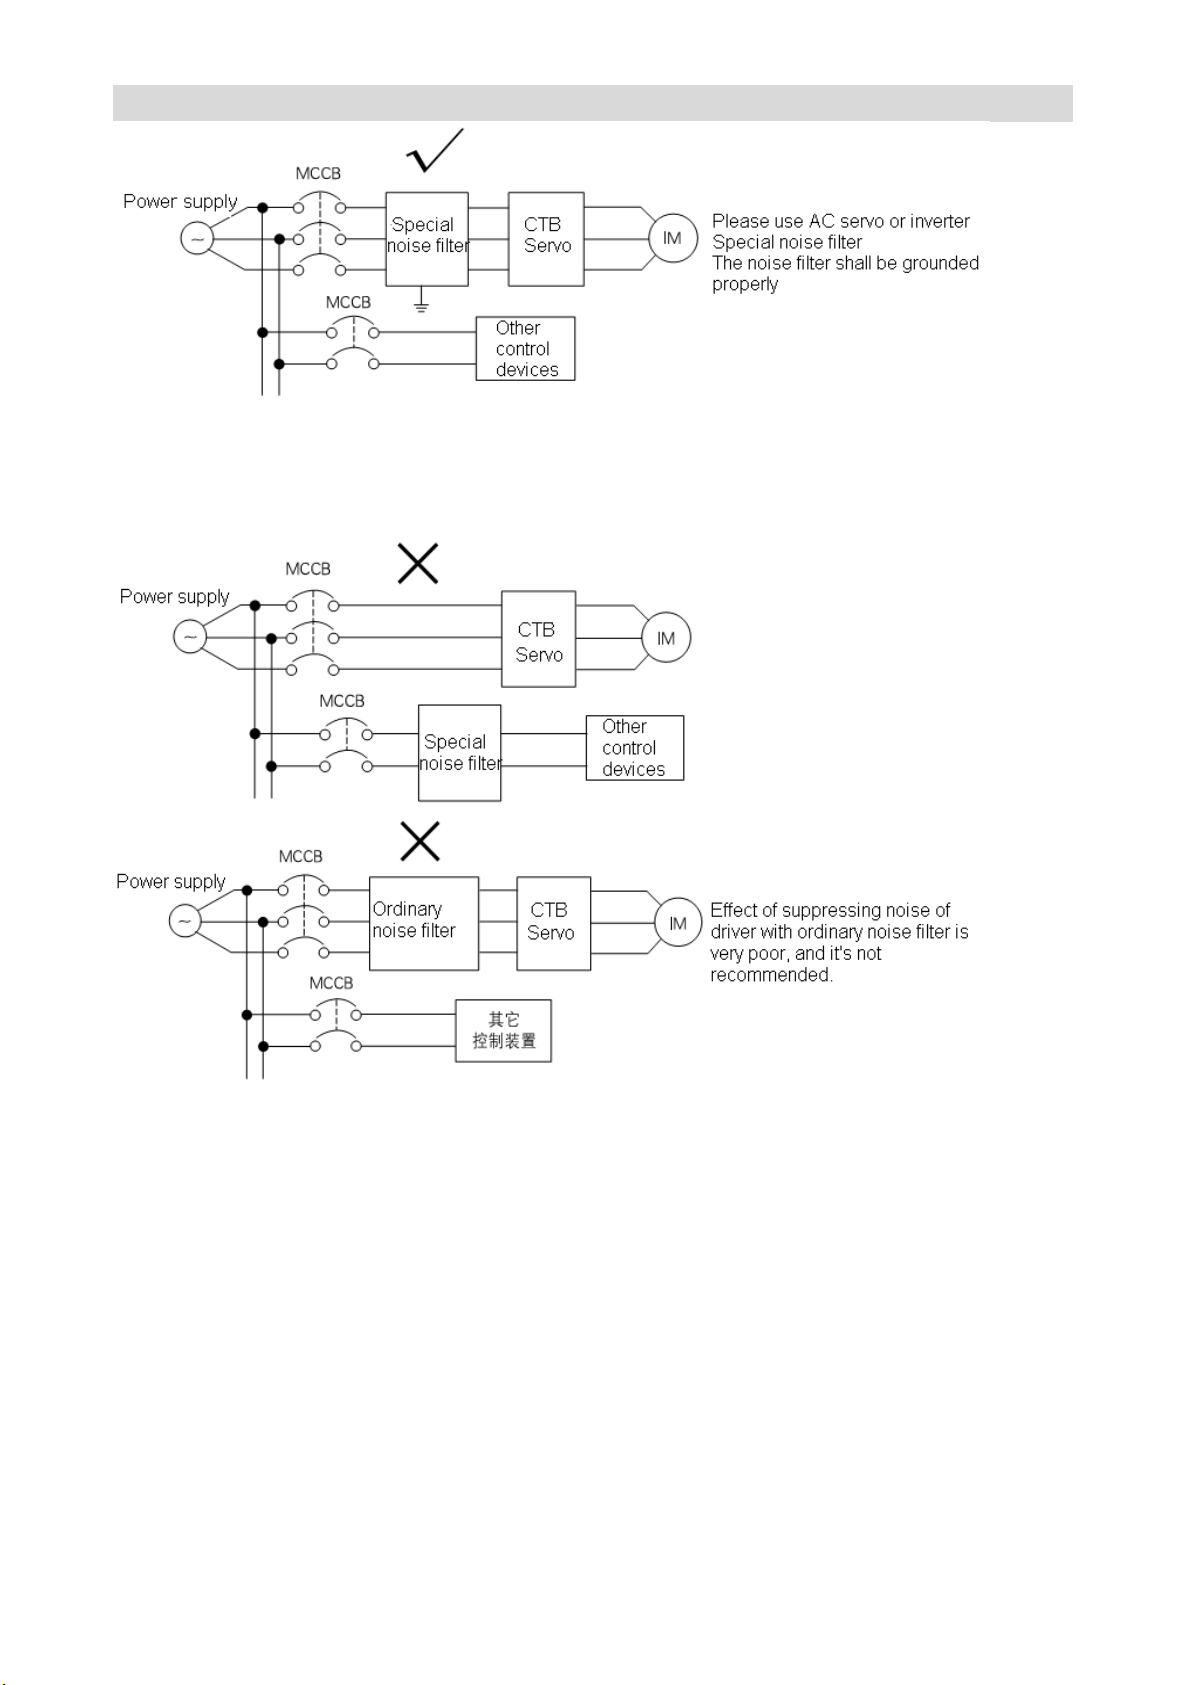
Power side noise filter
In command to reduce high-frequency interference noise from power line coupling to the
driver, and suppress the noise feedback to power from the driver, noise filter with
appropriate model and specifications at the power input side of the driver.
Set and connect the incoming line filter correctly as shown in Figure 2-6.
Page 30
GS DRIVER CTB
Figure 2-6 Correct installation of noise filter at the input side of the power supply
Please see Figure 2-6 for examples of incorrect settings and connection
Figure 2-7 Incorrect settings and connection of noise filter at the input side of the power
supply
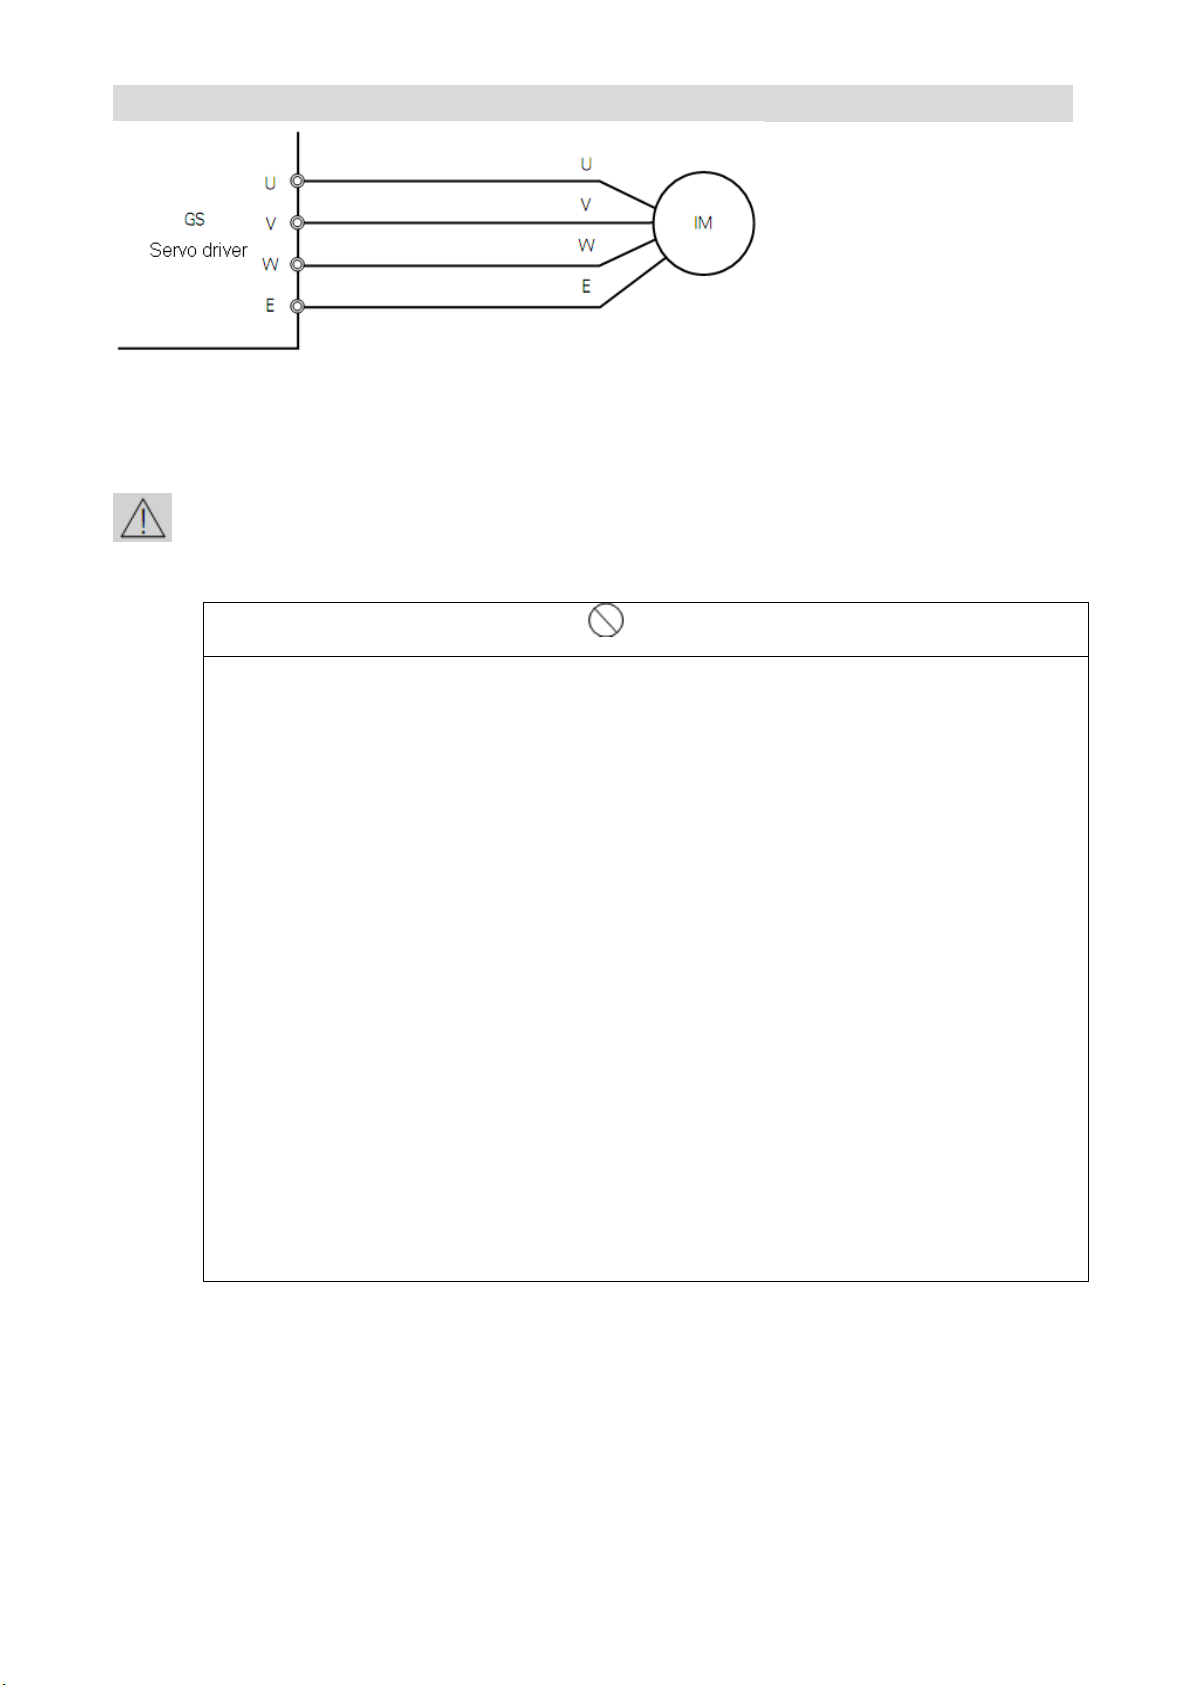
The wiring of output side of main circuit
The output terminals of U, V, and W of the driver shall be connected to the connecting
terminals of U, V, and W of three-phase AC motor by correct phase sequence; if the phase
sequence is connected wrongly, the driver will raise the wrong phase sequence alarm with
an alarm number of E.PV. To solve the problem, exchange phase sequence of any two
phases. Please see Figure 2-8 for standard wiring of the output side.
Page 31
GS DRIVER CTB
Figure 2-8 Output side wiring
Caution The servo driver and motor must be well grounded, otherwise it may make
the driver not functioning properly, even burn the driver.
Forbid
● It's strictly prohibited to connect the input power cord to the output terminal.
Never connect the input power cord to the output terminal, otherwise, it will lead to
damage to internal components of the controller.
● It's strictly prohibited to connect make the output terminal shorted and
grounded.
Never touch the output terminal directly, or make the output line touch the
controller housing for risk of electric shock. In addition, never short the output line.
● It's strictly prohibited to use phase shift electrolytic capacitor, LC / RC noise
filter.
Never connect phase shift electrolytic capacitor, LC / RC noise filter in output
circuit. Damage to internal components of the controller may be caused when use
these components.
● It's strictly prohibited to connect or disconnect load with electromagnetic switch.
Never connect electromagnetic switch, electromagnetic contactor to connect or
disconnect the load in output circuit. During load operation, the protection circuit
action of the controller will be acurated by the surge current.
surge current will arose
● It's strictly prohibited to connect fan of spindle motor to U / V / W output
terminals of the driver.
It may burn the fan, and short-circuit the driver.
Wiring distance between the driver and motor
Generally, the wiring distance between the servo driver and motor shall be shorter than 50
m. For longer distance, please contact the manufacturer to select wire with samller
resistivity.
Page 32
GS DRIVER CTB
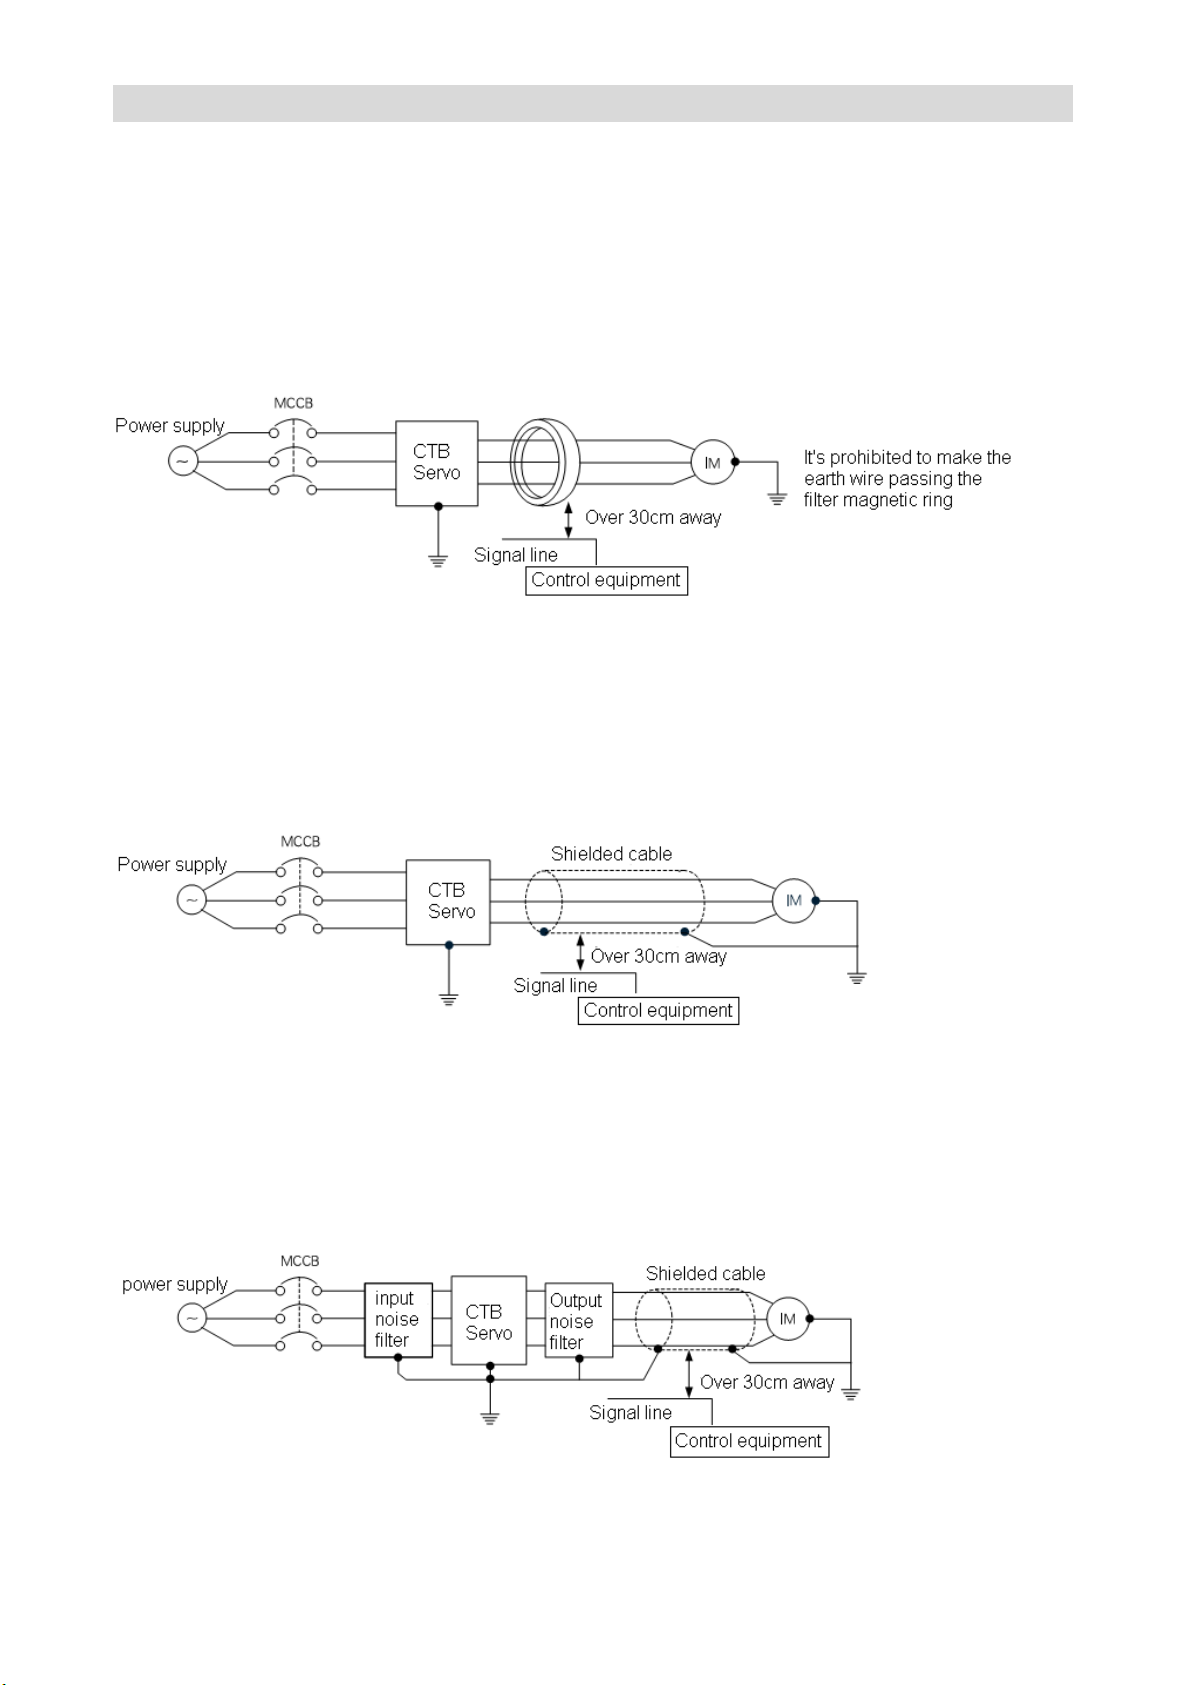
Inductive interference countermeasures
Three methods of suppressing radio interference and inductive interference are provided in
the information: filter magnetic ring, shielded cable and output filter.
Filter magnetic ring
Installing filter magnetic ring at the output side near to the driver can suppress common
code interference at the output side effectively, as shown in Figure 2-9.
Figure 2-9 Filtering magnetic ring installation diagram
Output shielded cable
Use shielded cable for output line of the servo driver can effectively suppress radio
interference and inductive interference. The ends of shielding layer of the shielded cable
shall be grounded separately as shown in Figure 2-10.
Figure 2-10 Connecting method of shielded cable
For applications of input and output filters in occasions with relatively large radio
interference, output filter can be used to suppress interference. The input side and the drive
generate radio interference so that the effect is best by using the input, output filter at the
same time, as shown in Figure 2-11.
Figure 2-11 Supress radio interference with output filter
Page 33
GS DRIVER CTB
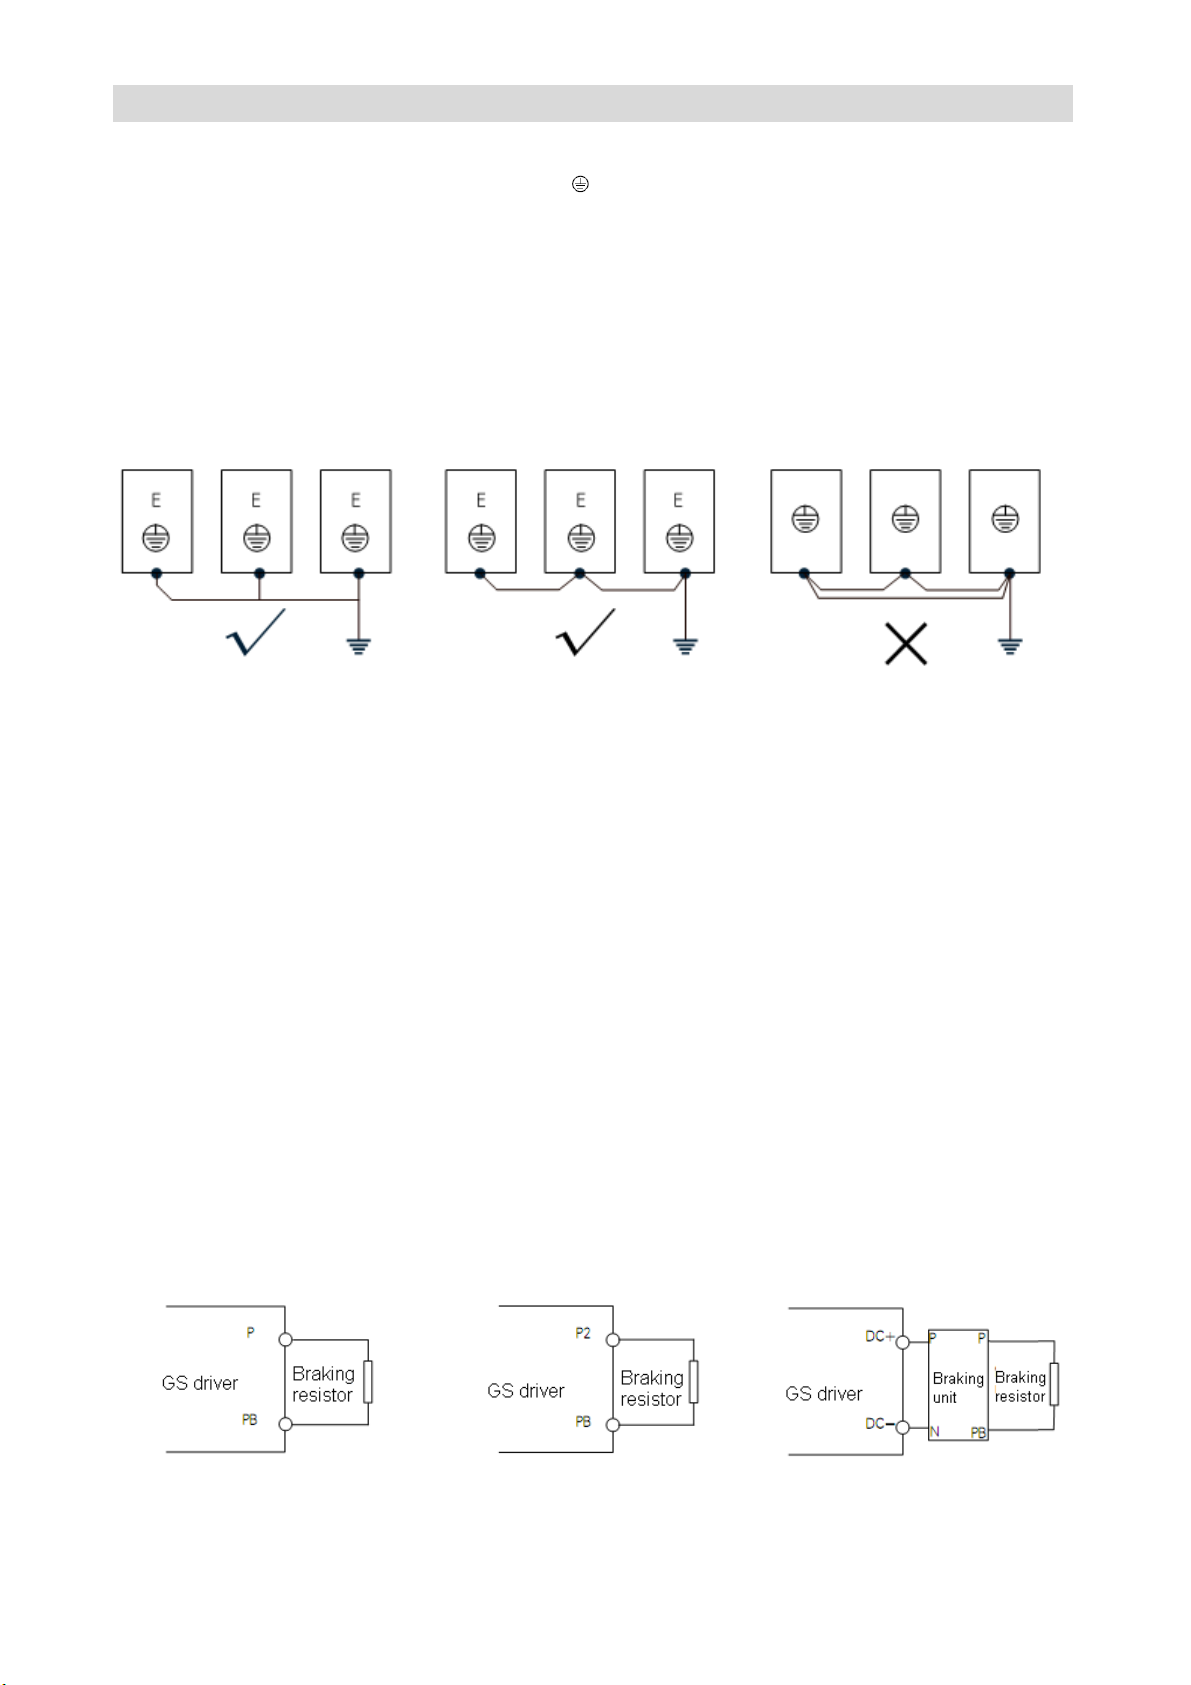
Connection of the grounding wire
● The ground terminal is identified as E or , please do ground.
● Earth resistance: below 4Ω.
● Do not share grounding wire with welder and other power equipment.
● Please select wire diameter specification for grounding wire as specification in technical
standards of electrical equipment, and as short as possible.
● Please make grounding wire forming a loop where more than two drivers are used.
● Example: as shown in Figure 2-12
Figure 2-12 Connection of grounding wire
Connection of braking resistor
The P, PB terminals on main circuit block of servo driver are for connection with braking
resistor. Please do not connect braking resistor to other terminals, otherwise, the braking
resistor will heat up and burn out, or cause damage to the driver. Please see Table 2-2 for
braking resistor selection.
● The connection of braking resistor shall be in strict accordance with Figure 2-13.
● The length of connecting wire between driver and braking resistor shall be less than 50
m.
● Please pay particular attention to: external braking unit may be connected to p (+) / DC +,
N (-) / DC side of the driver, but direct connecting with braking resistor is not allowed,
otherwise, damage to driver or fire may be caused.
1.5 ~ 15kw braking resistor
wiring diagram
18.5 ~ 75kw braking resistor
wiring diagram
90 ~ 150kw braking resistor
wiring diagram
Figure 2-13 Connection of braking resistor
Page 34
GS DRIVER CTB
e
e
Table 2-3 Specification of braking resistor
BKSC-XXXX GSX 41P5 42P2 43P7 45P5 47P5 4011 4015 4018 4022 4030 4037 4045 4055 4075 4090 4110 4132 4160 4185 4220 4315
Power W 400 1000 1000 1500 2000 2000 1500 2000 2000 2500 2500 2500 2500 2500 2500 2500 2000 2000 2000 2000 2000
ripple
Braking
resistor
aluminum
housing
inside diameter φ(mm)1 5 1 5 1 5 1 8 1 8 23 23 23 27 27 38 38 38 38 38 44 44 44 ― ― ― Filtering
magnet
Thickness H(mm) 13 13 13 13 13 15 15 15 15 15 24 24 24 24 24 15 15 15 ― ― ―
ring
Note: above accessories data is standard data recommended by the manufacturer. For
special applications, please contact your supplier.
Selection of breaker, contactor and cable
esistanc
Power W 300 300 600 600 800 1000 600 800 800
esistanc
300 160 40 40 32 32 40 40 40 55 55 55 55 55 55 55 40 40 40 40 40
Ω
Qty. 1 1 1 1 1 1 2 2 2 3 3 3 4 6 8 8 10 1 2 1 2 1 2 1 6
100 100 50 50 40 32 50 40 40
Ω
Qty. 1 1 1 1 1 1 2 2 2
Same parameters for ripple resistor
Please see Table 2-3 for selection of breaker, contactor and input and output cable
Table 2-3 Specification of breaker, contactor and cable
Model
BKSC
Power
(kW)
Breaker
(air switch) (A)
Main circuit cable
(copper conductor
cable) (mm
2
)
41P5GS□ 1.5 10 2.5 9
42P2GS□ 2.2 10 2.5 9
43P7GS□ 3.7 16 4 16
45P5GS□ 5.5 32 4 18
47P5GS□ 7.5 40 6 25
4011GS□ 11 63 10 32
4015GS□ 15 63 16 50
4018GS□ 18.5 100 16 63
4022GS□ 22 100 25 80
Contactor
Voltage: 380V.
Current:(A)
4030GS□ 30 125 35 95
4037GS□ 37 160 35 115
4045GS□ 45 200 50 115
4055GS□ 55 200 70 150
4075GS□ 75 250 95 185
4090GS□ 90 315 95 250
Page 35
GS DRIVER CTB
4110GS□ 110 400 120 250
4132GS□ 132 400 150 315
4160GS□ 160 630 185 400
Main circuit wiring precautions
● Please do connect breaker or fuse between power supply and power input terminals (R,
S, T) of the driver.
● Please do connect to earth wire at E terminal of the driver. Copper core cable over 4mm2
shall be used for earth wire with a grounding resistance lower than 4Ω.
● Please ensure the high reliability of wiring.
● Please check the following items after circuit wiring.
(1) Are all connections correct?
(2) Is there connection missing?
(3) Is there short circuit between terminals and connecting line or shorted to ground?
Control circuit wiring
Input and output signals of GS Series servo driver include: switching value input signal,
switching value output signal, analog quantity input signal, PULSE input signal, encoder
input / output signal.
Specifications of input and output signal cable
As the control signals are different, the requirements to cable for connector are strict.
Specifications of cable for different signal connectors are listed in Table 2-4. User shall
follow the standard for wiring.
Table 2-4 Specifications of input and output signal cable
Signal Signal name Cable
switching value
input /output
Relay output M0A/M0b/M0c M1A/M1b/M1c
analog quantity
signal
i1~i6 Q0~Q1
FI FV FS Fc FS FT shielded cable 0.2~1
common cable or
common cable or
shielded cable
shielded cable
Cable
specification
0.2~2
0.2~2
Encoder signal
PULSE signal SA+ SA- Pb+ Pb- Dz+ Dz-
enable reset
signal
PV1 G1 A+ A- B+ B- Z+ Z-
PV2 G2 OA+ OA- OB+ OB- OZ+ OZ-
ST
Shielded twisted
twin cable
Shielded twisted
twin cable
common cable or
shielded cable
0.2~1
0.2~1
0.2~1
Page 36
GS DRIVER CTB
GS □ driver control panel specifications
GS Series driver provides two kinds of control board according to different power and
function of GS Series driver. Please see Table 2-5 for interface characteristics and
applicable model.
Table 2-5 GS □ driver main board specifications
Control
panel
model
cP100c 6 4 3 ○ RS232 ○ ○
cP100b 4 4 - ○ RS485/TcP/iP ○ ○
cP100A 6 4 3 ○ RS232 ○ ○ 1.5-15Kw
switching
value
input
switching
value
output
analog
quantity
input
PULSE
input
Communication
interface
Encoder
input
Encoder
input
Applicable
power
18.5~160Kw
Page 37
GS DRIVER CTB
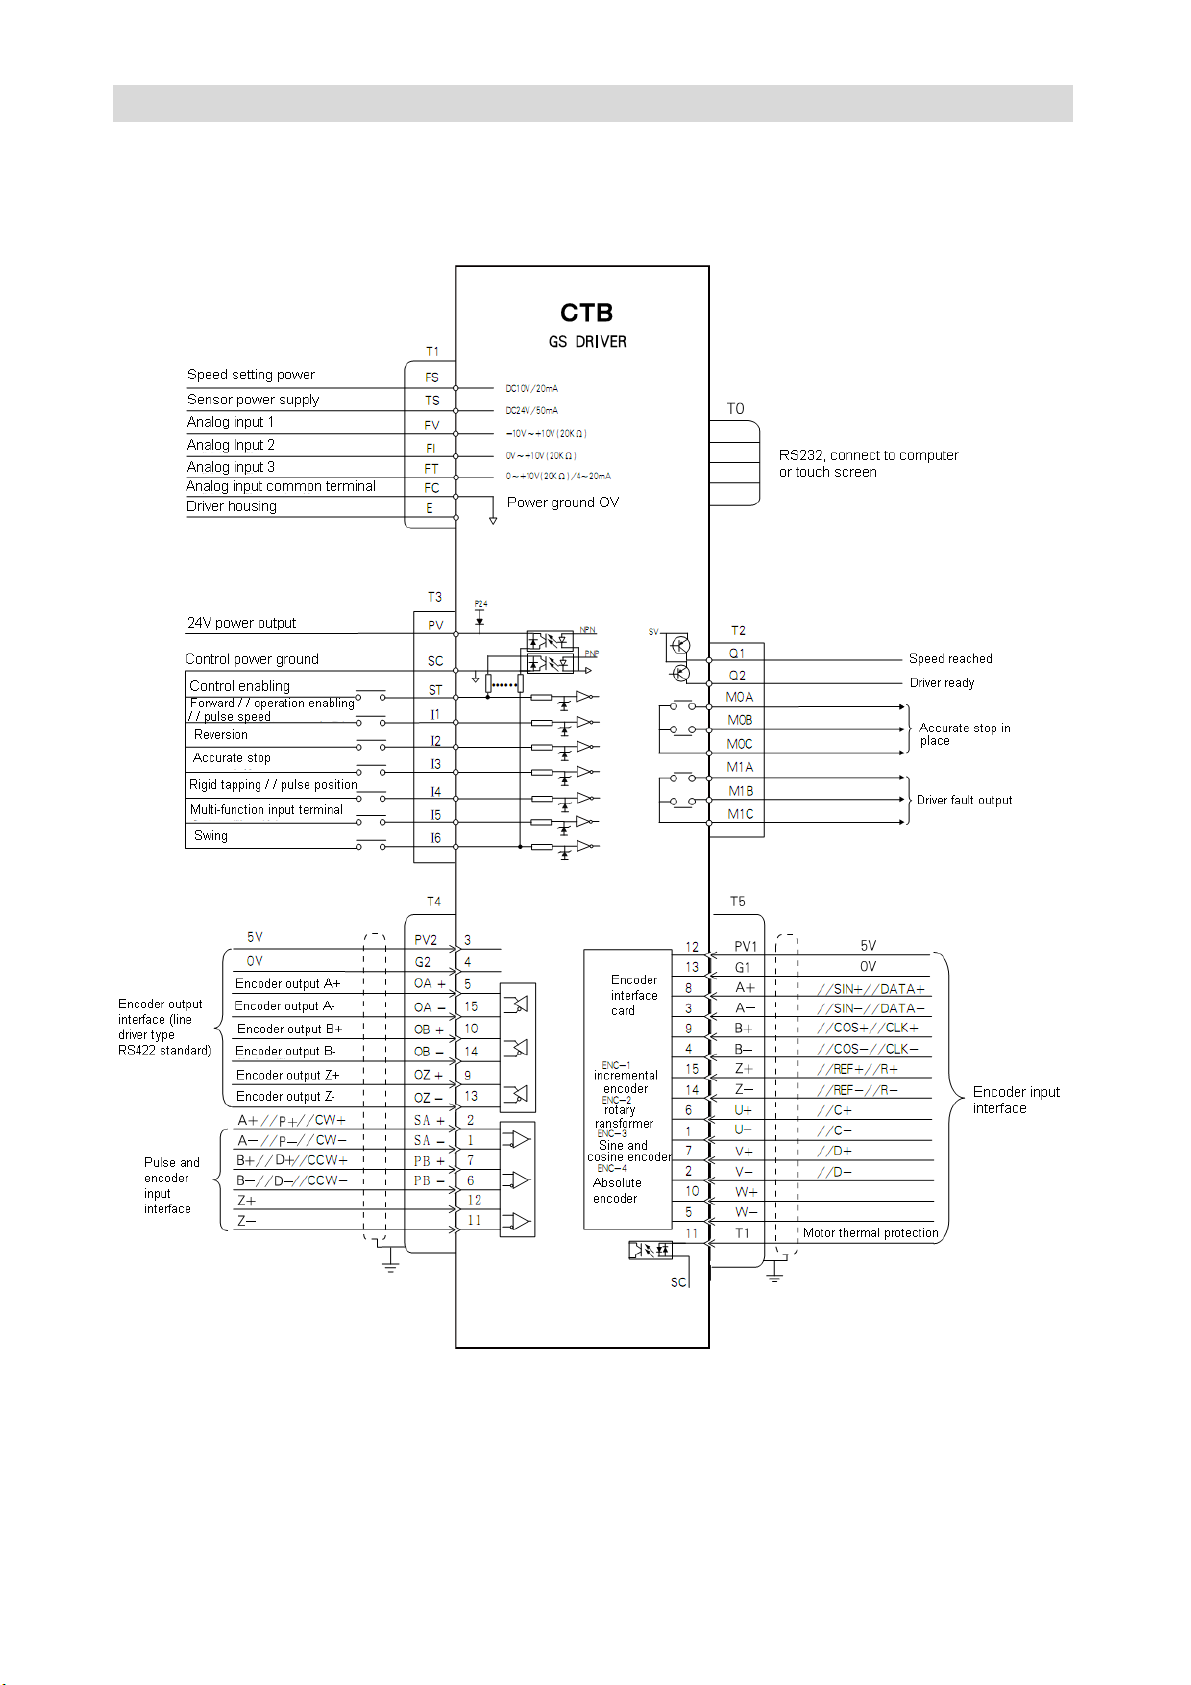
Control signal wiring diagram
Wiring diagram of GS □ driver equipped with CP100 series main board
Input and output signals description (CP100 Series)
Table 2-6 Input and output signal function description
Page 38
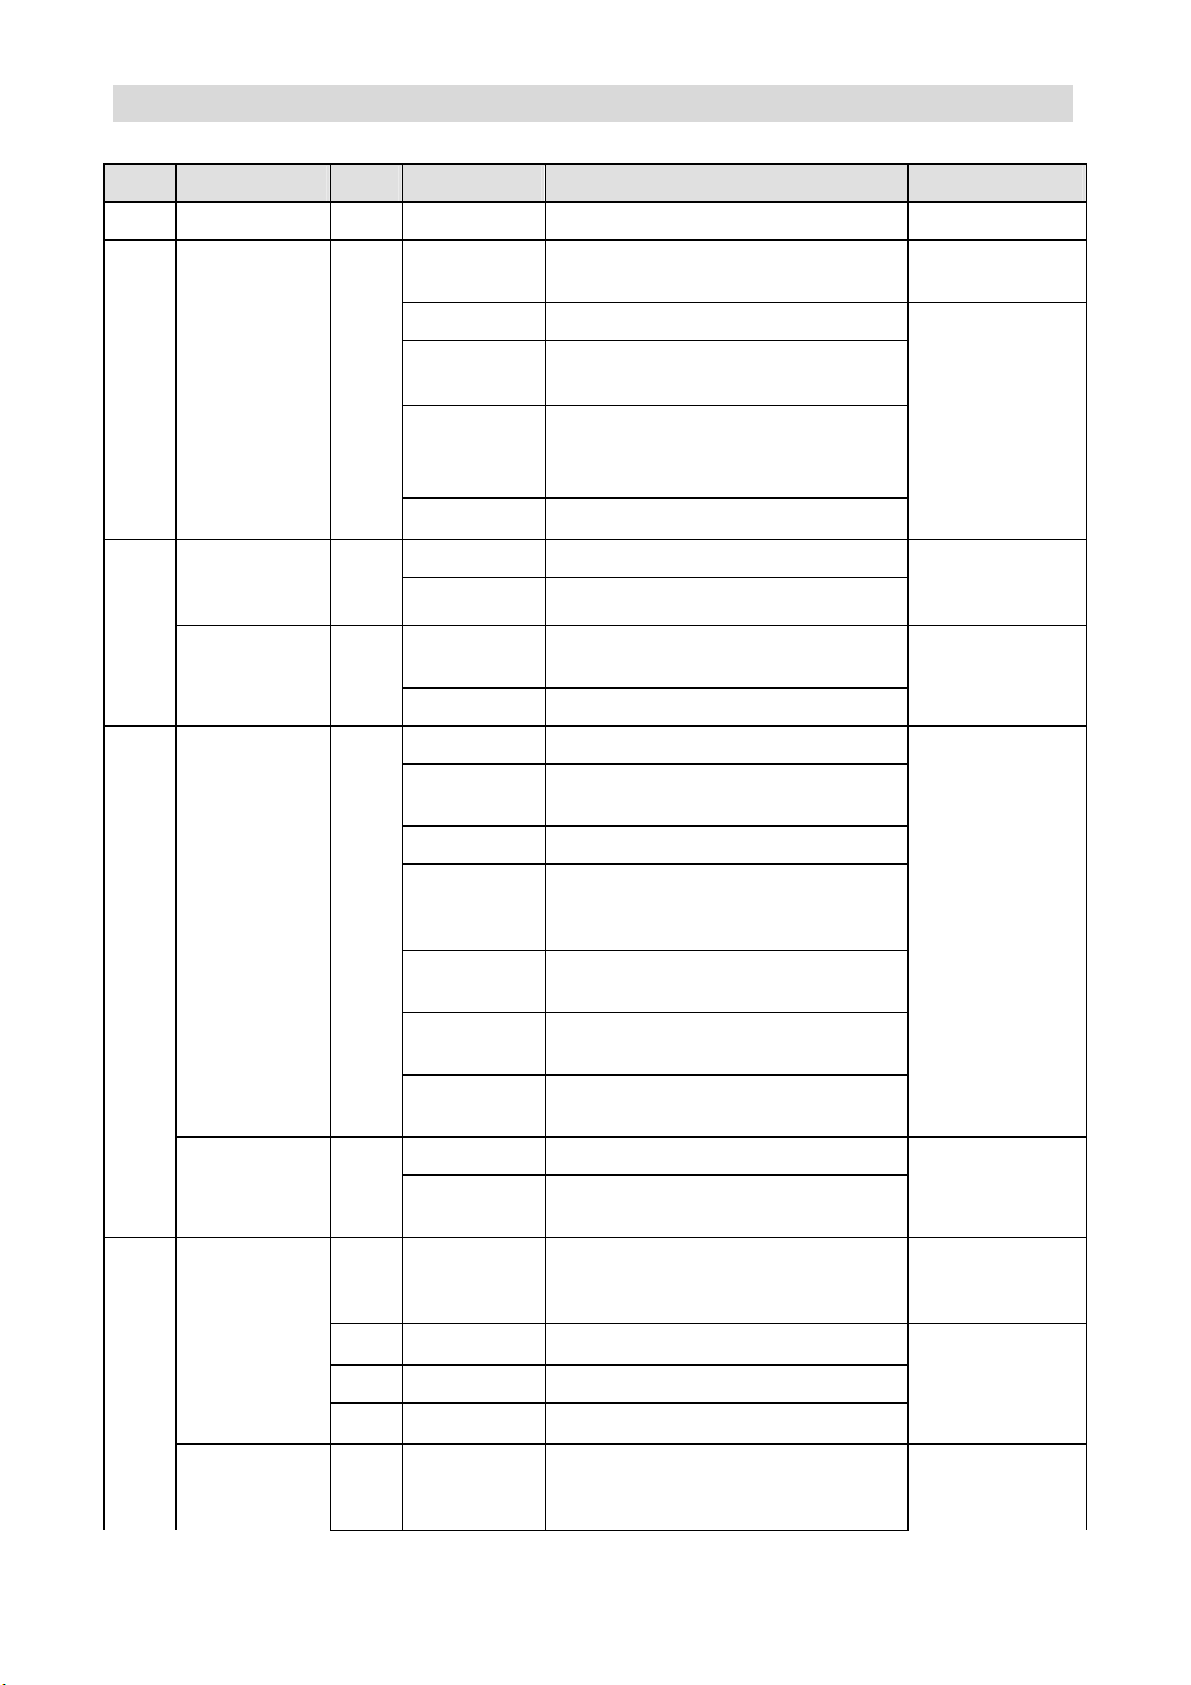
GS DRIVER CTB
Port Type Pin Name Function Signal standard
T0 Communication communicate with computer RS232
T1 Analog input
optocoupler
output
丁 2
Relay output
Control signal
input
T3
MIA/MIb/MIc driver fault output
FS
Fc analog input /output
FV
Fi
FT 0~10V analog input
Q1 speed reached Programmable
Q2 driver ready
MOA/MOb/M
Oc
ST control enabling and reset
i1
i2 reverse operation direction
i3
i4
i5
10V power for speed setting is
provided inside common port
-10V ~ +10V analog input, input
impedance: 20KΩ
Analog input impedance may be
selected for 0 ~ 10V , 4 ~ 20mA
impedance: :20K/500Ω
output accurate stop end (in place)
output
foreword operation enabling PULSE
speed
accurate stop, close: start accurate
stop and maintain; open: cancel
accurate stop
rigid tapping signal, close : enter rigid
tapping state
Swing signal, close: enter swing state
for mechanical shifting
Dc10V 50mA
0V
24V optocoupler
output 10mA
Ac250V 1A
Dc30 1A
PNP: 0V input
effective
NPN:24V input
effective
Input mode of
PNP or NPN
Shall be selected
by software
parameter setting
i6
PV DC24V power output terminal
Control power
T4
Encoder output
Encoder
PULSE input
3/4 PV2/G2
5/15 OA + OA- encoder A phase output
10/14 Ob + Ob- encoder B phase output
9/13 Oz + Oz- encoder Z phase output
1/2
Sc
SA + SA-
multifunctional terminal (can be
defined)
DC24V power 0V terminal /control
signal common port
Preset power, provided by digital
system, system without electrify
inspection may go without.
encoder A phase/orthogonal PULSE
A phase input /single PULSE train
input P
Dc24V 500mA
Dc5V,100mA
line driver output
RS 422 standard
RS422/485
standard
Page 39
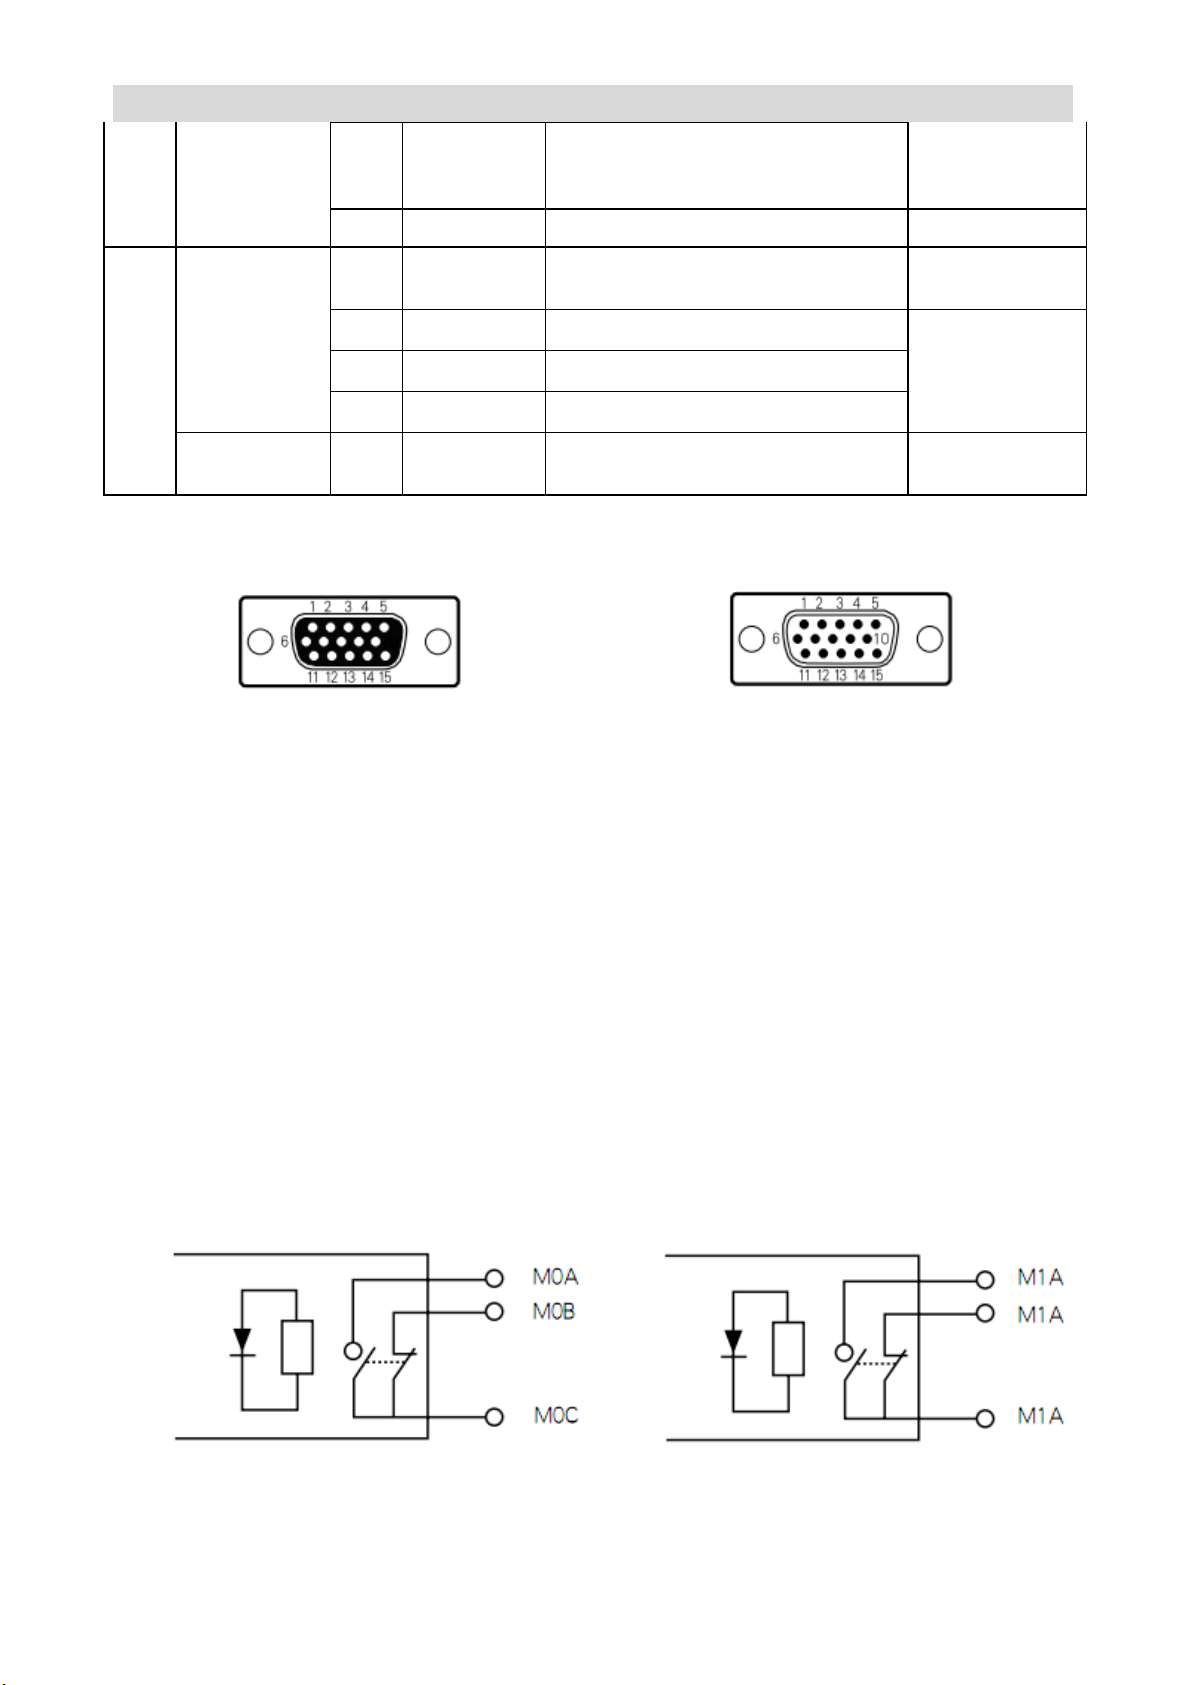
GS DRIVER CTB
encoder B phase/orthogonal PULSE
7/6
12/11 Dz + Dz- encoder Z phase
Pb + Pb-
B phase input /single PULSE direction
input D
encoder power supply provides
terminal /power common port
Dc5V 100mA
line driver accepts
RS422standard
Communication
encoder input
T5
protection input
Thermal
12/13 PV1/G1
8/3 A + A- encoder A phase input
9/4 b + b- encoder B phase input
15/14 z + z- encoder Z phase input
11 T1 Motor thermal protection signal input N.C./ N.O.
Connector terminal arrangement
T4 D-type 15-pin plug (pin)
T5 D-type 15-pin plug (hole)
Control power supply wiring
In addition to analog control terminal, all of other control terminals of GS series servo driver
are equipped with optocoupler isolation. Power of the optocoupler isolation may select from
internal of the driver or external power provided by the user according to the actual
requirements. To ensure better isolation effect, it is recommended to use external DC24V
isolation power provided by user.
The wiring of relay output signal
T3 interface of GS servo driver provides two relay output points.
Output standard: AC250V 1A DC30V 1A
Accurate stop relay output schematic diagram
Fault relay output schematic diagram
Transistor output wiring precautions
● The maximum oad capacity of output tape of transistor output QI/Q2 is 20 mA, and the
Page 40
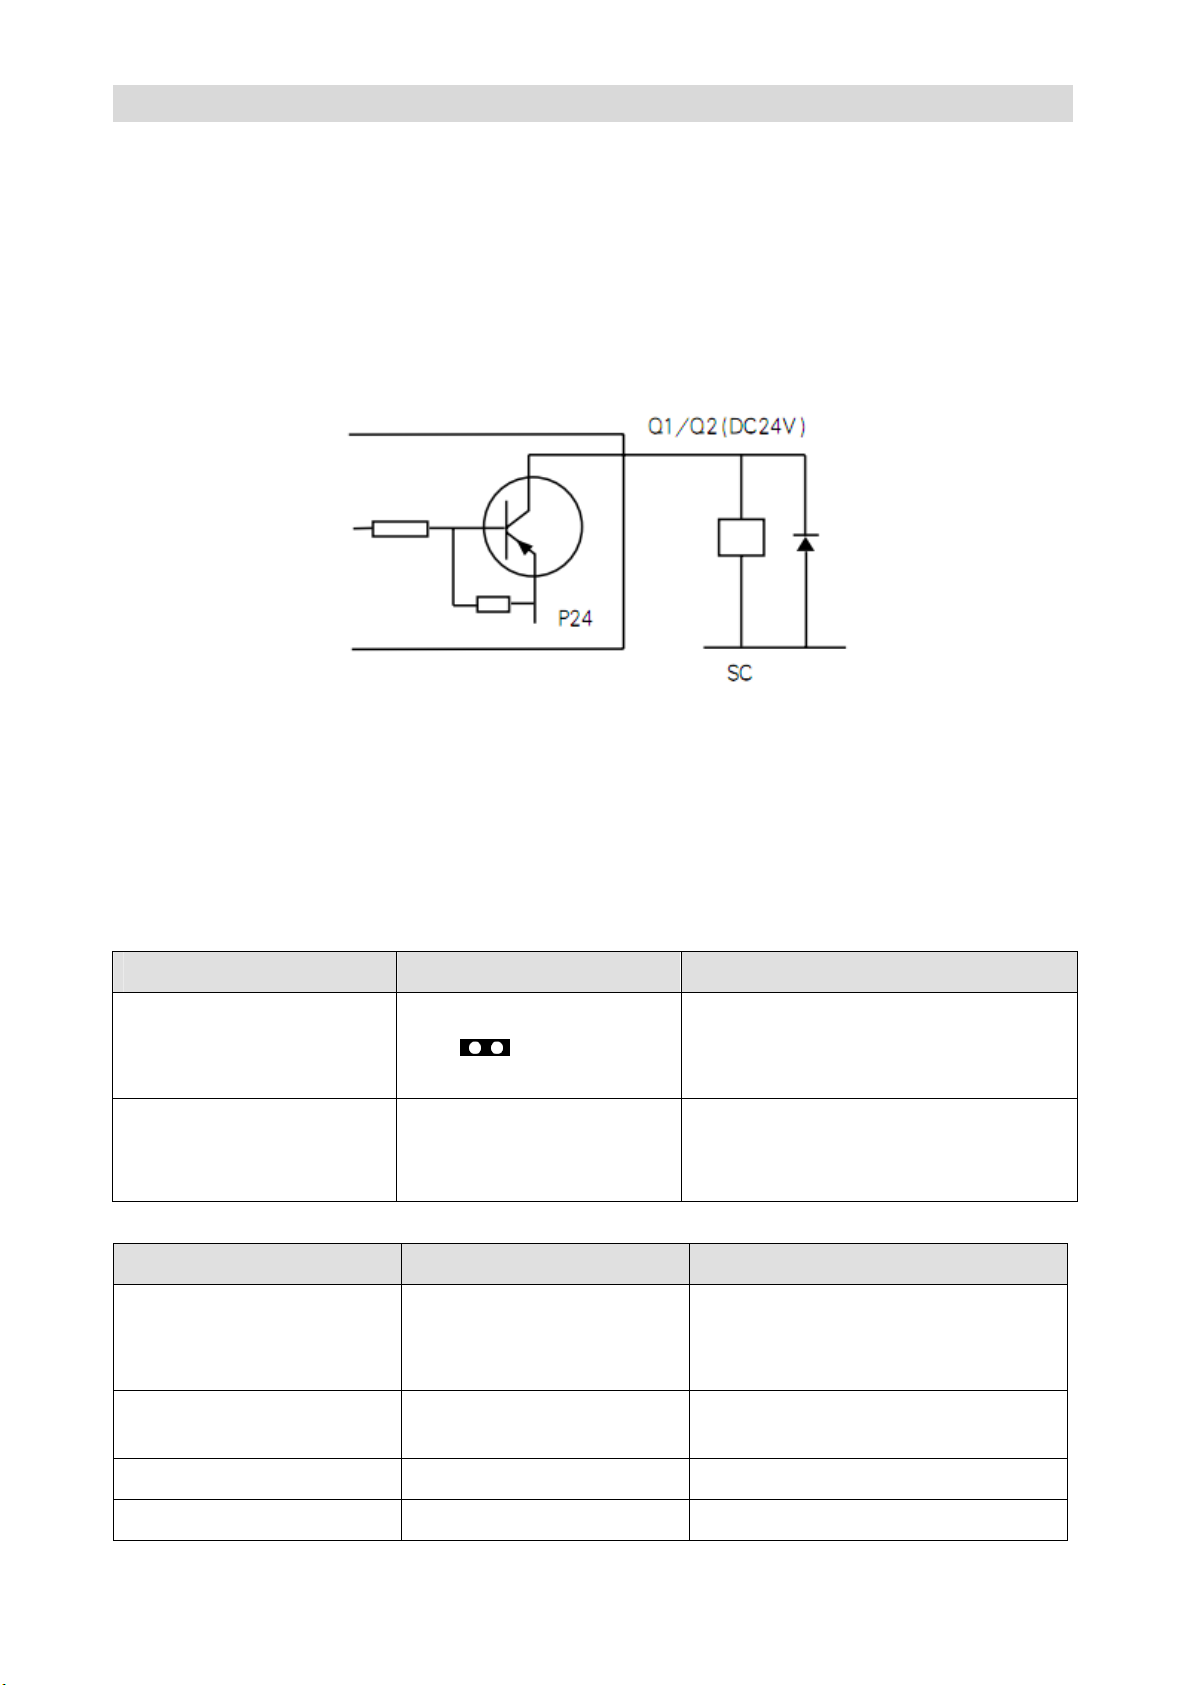
GS DRIVER CTB
output voltage is DC24V.
● If the output terminal needs 0V, intermediate relay may be installed for switching as
shown in Figure 2-14.
● If the output terminal drives inductive load (e.g., electromagnetic relay, intermediate
relay), surge voltage absorbing circuit shall be added as shown in Figure 2-14.
If follow current diode is installed in surge absorption circuit (for DC electromagnetic circuit),
attention must be paid to polarity during installation.
Figure 2-14 Transistor output circuit
Wiring of analog input signal
When GS □ servo driver selects C P100A/C P100B/C P100C main board, T1 port provides
three sets of analog input interfaces of FI, FV and FT, as well as a group of power interface
FS and fc for analog input. Please see Table 2-6 for signal function description.
Table 2-6 Analog interface signal description
Signal Function Signal standard
Select 4~20mA input
FT
FI
Signal Function Signal standard
j1
Unipolarity analog input
and plug J1
jumper
terminal
Bn02=1
Unipolarity analog input terminal
4~20mA, input impedance: 250Ω
0~10V, input impedance: 20KΩ
Bipolarity analog input
FV
FS
Fc analog common port 0V
E
inside provided speed
terminal
Bn02=0
setting power
Shielding layer
-10V~+10V analog input,
input impedance: 20KΩ
DC10V,50mA,
Page 41
GS DRIVER CTB
connecting terminal
Wiring requirements
● Connect to signal source or control signal with multi-core shielded cable or stranded
shielded wire.
● The near-end of shielding layer of the case (end near the driver) shall be connected to the
connector housing.
● During wiring, the control cables shall be arranged more than 30cm away from the main
circuit and strong power line (including power line, motor line, relay, contactor connecting
cable), and avoid parallel layout. Vertical wiring is recommended to prevent malfunction of
the driver due to interference.
●Filter magnetic ring provided by the manufacturer shall be used for long distance wiring. It
shall be installed at the side near the driver.
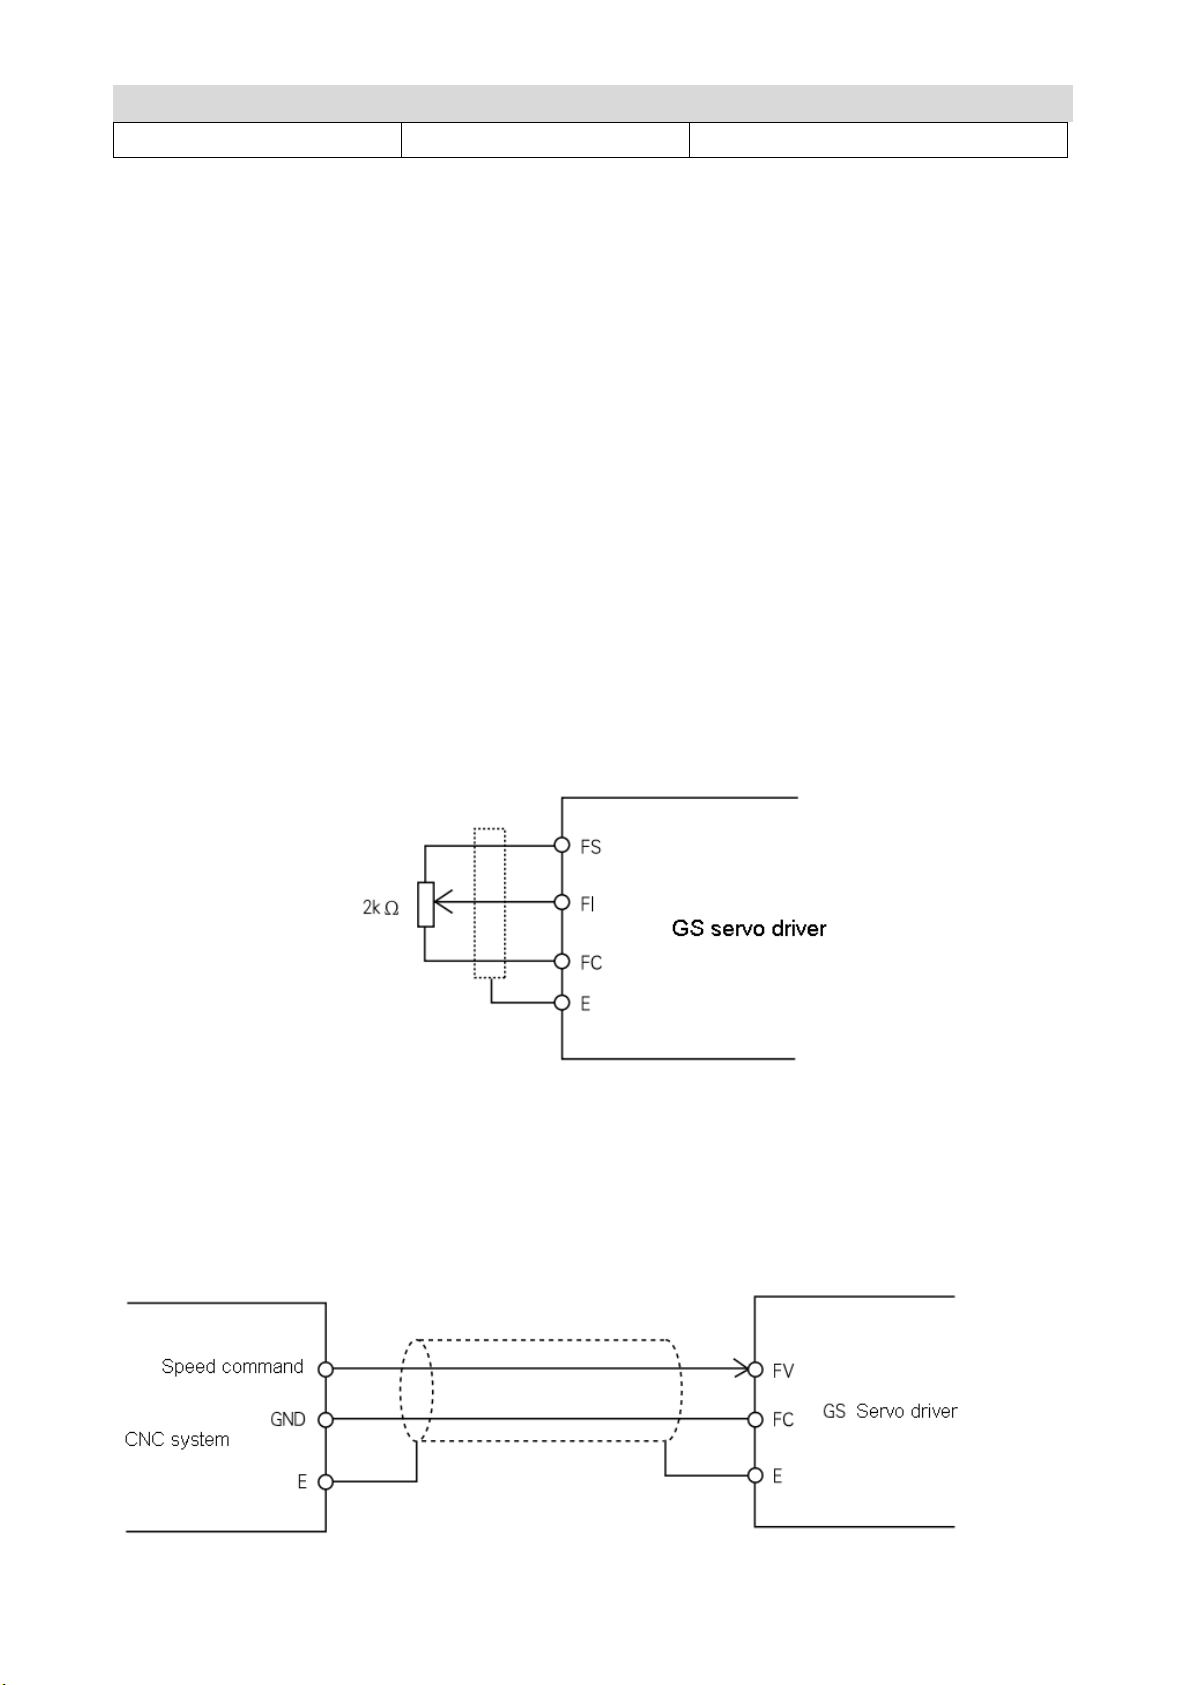
FI terminal wiring example
Use internal power for speed setting. The input signal is 0 ~ 10V as shown in Figure 2-16.
Figure 2-16 Conduct speed setting with internal power
FV terminal wiring example
CNC system uses bipolar (-10V ~ +10 V) analog output. The speed is determined by the
value of the analog, the direction of rotation is determined by polarity of the analog as
shown in Figure 2-17.
Page 42
GS DRIVER CTB
Figure 2-17 Bipolar speed setting is conducted by CNC system
Forbid
● It's prohibited to connect the signal line and OV reversely. The signal line is likely
to be burned, and reverse operation may be caused for bipolar.
● It's prohibited to connect high-voltage to analog signal terminal. The driver may
be burned.
Connection of the encoder interface
A group of encoder input interface T5 and encoder input interface T4 are provided on main
board of GS series servo driver. Please see Table 2-7 and Table 2-8 for interface definition.
Table 2-7 Encoder input interface T5
Signal Description Signal standard
PV1 Encoder power supply DC5V
G1 Encoder power ground 0V
A+ A phase PULSE same-phase input (+)
A- A phase PULSE same-phase input (-)
B+ B phase PULSE same-phase input (+)
B- B phase PULSE same-phase input (-)
Z+ Z phase PULSE same-phase input (+)
Z- Z phase PULSE same-phase input (-)
T1 Motor thermal protection input terminal 24V optocoupler isolation input
DC5V/100mA
Line drive mode
RS422 standard
Table 2-8 Encoder input interface T4
Signal Pin Description Signal standard
PV2 3
G2 4 Encoder power ground 0V
OA+ 5 A phase PULSE same-phase input (+)
OA- 15 A phase PULSE same-phase input (-)
Encoder power supply
DC5V
Or external sensor
power
DC5V/100mA
OB+ 10 B phase PULSE same-phase input (+)
OB- 14 B phase PULSE same-phase input (-)
OZ+ 9 Z phase PULSE same-phase input (+)
OZ- 13 Z phase PULSE same-phase input (-)
SA+ 2 PULSE/encoder A phase input (+)
SA- 1 PULSE/encoder A phase input (-)
PB+ 7 PULSE/encoder B phase input (+)
PB- 6 PULSE/encoder B phase input (-)
Line drive mode
RS422 standard
Line drive mode
RS422 standard
Page 43
GS DRIVER CTB
DZ+ 11 PULSE/encoder Z phase input (+)
DZ- 12 PULSE/encoder Z phase input (-)
Encoder wiring precautions
● The encoder cable must be shielded twisted pair cable. Please see Table 2-4 for cable
requirements.
● The shielding layer shall be connected to the connector housing.
Forbid
●It's prohibited to connect the DC5V power reversely. It's likely to burn the DC5V power or
encoder of the driver.
●It's prohibited to reverse the A, B phase sequence. Otherwise, the motor will not function
properly, or even burn the motor or driver.
Connection of serial communication port
GS driver provides users with a R S232A serial communication interface T0 for connection
with computer to realize transmission of program and parameters. The port is connected
with computer through RS232-P1 cable.
Please see Table 2-9 for definition of serial communication interface T0
Table 2-9 T0 interface definition
Pin Name Description Pin Name Description
1 4
2 5 Send terminal
3 Receive terminal 6 Used by manufacturer
T0 interface diagram
General Purpose cable model: rs 232-p1
Caution
● Please select the standard cable provided by the manufacturer for communication.
Page 44
GS DRIVER CTB
Manipulator application
The chapter describes the functions and methods of application of the manipulator.
0.4 ~ 18.5kw driver:
Configuration and key functions of the manipulator……………….3-2
Operative mode of the driver…………………………………………3-3
Operative mode of the manipulator………………………………….3-4
Use method of the manipulator………………………………………3-5
Modify the parameters with the manipulator………………………..3-6
Monitor operating state with the manipulator……………………….3-7
22 ~ 315kw driver:
Configuration and key functions of the manipulator………………..3-8
Operative mode of the driver…………………………………………3-10
Operative mode of the manipulator………………………………….3-10
Use method of the manipulator……………………………………...3-12
Modify the parameters with the manipulator……………………….3-12
Monitor operating state with the manipulator………………………3-13
Page 45
GS DRIVER CTB
Configuration and key functions of the 0.4 ~ 18.5kw manipulator
The chapter defines and describes terms and phrases for operation and state of 0.4 ~
18.5kw driver manipulator, defines the operation methods of driver and manipulator. Please
read carefully. It's very helpful for proper use of the 0.4 ~ 15kw driver.
Manipulator
The manipulator is one of the standard equipment of 0.4 ~ 18.5kw driver. User may carry
out parameter setting, state monitoring, operation control and other operations to the driver
through the manipulator. It's very important to be familiar with function and operation of the
manipulator for proper application of 0.4 ~ 18.5kw series driver. Please read the manual
carefully before using.
Manipulator appearance diagram
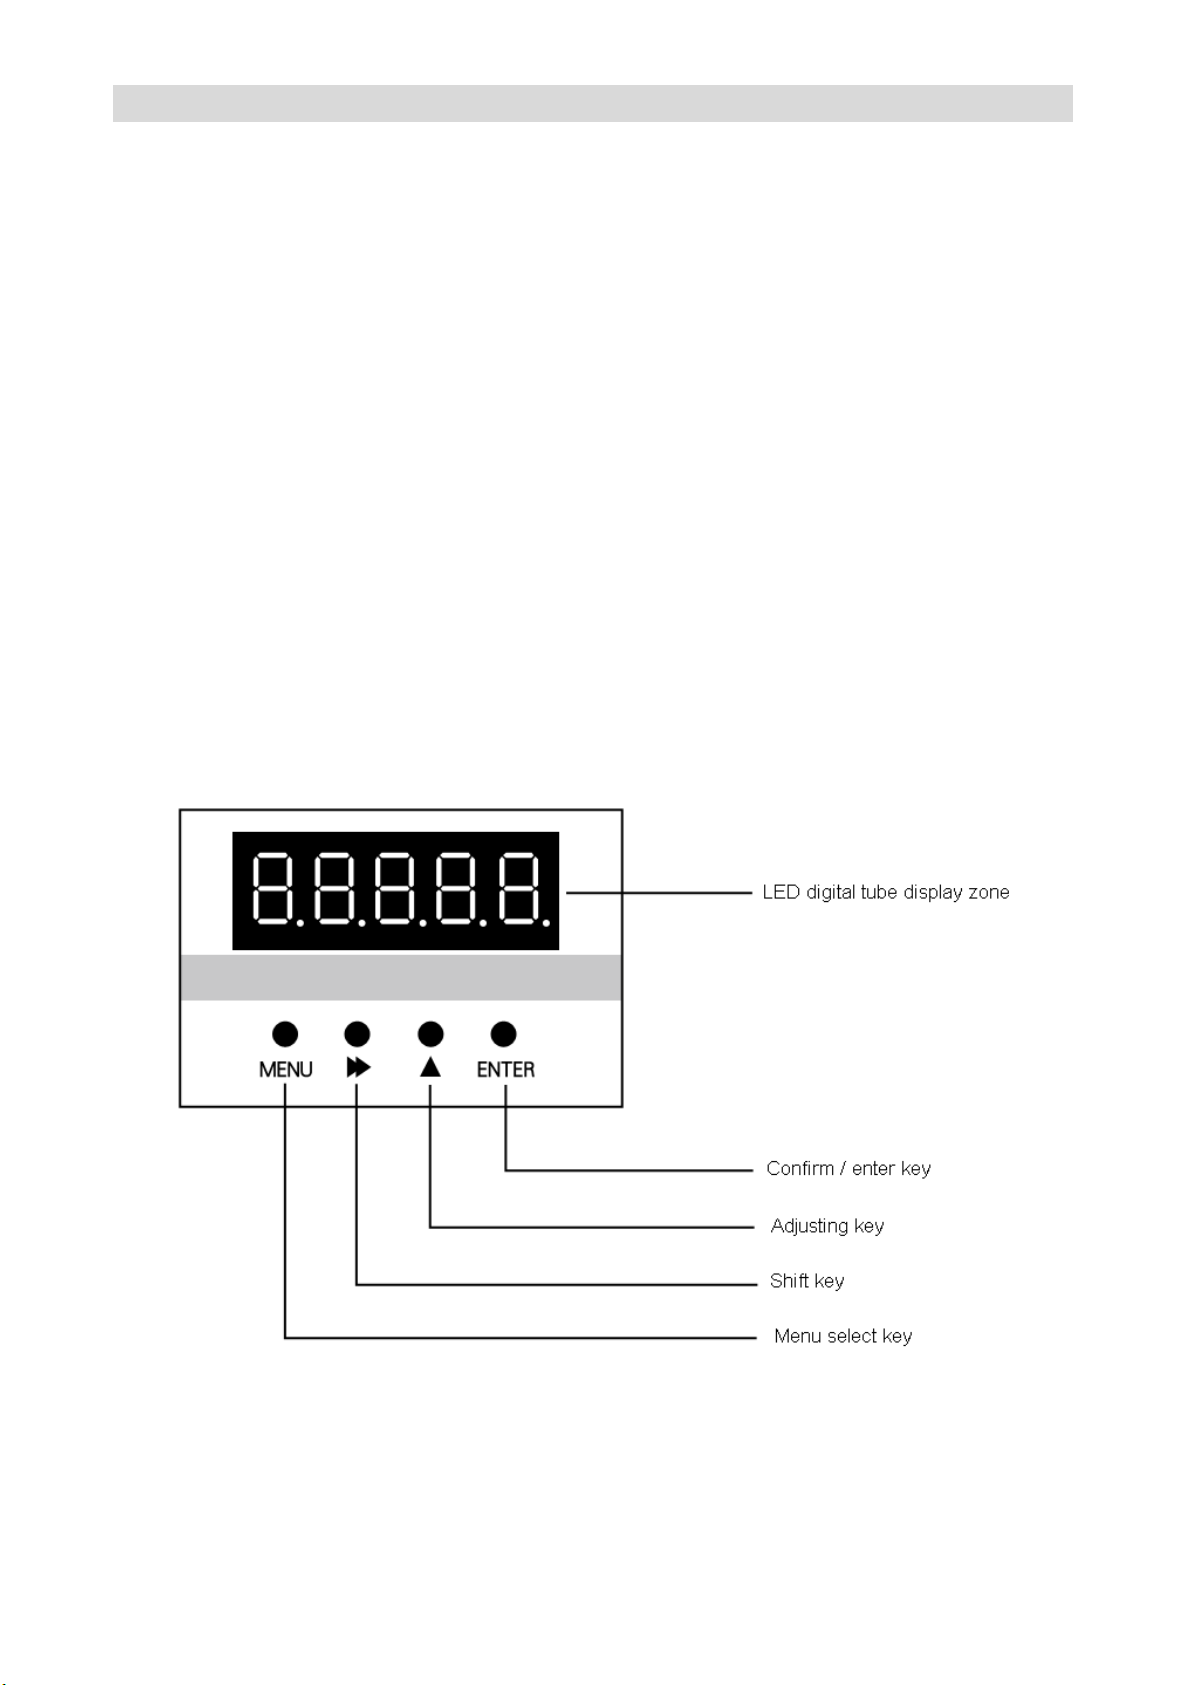
Manipulator of 0.4 ~ 18.5kw driver is mainly composed of two parts of LED digital tube and
keys. The appearance and functional zones are shown in Figure 3-12.
Figure 3-12 Manipulator diagram
Page 46
GS DRIVER CTB
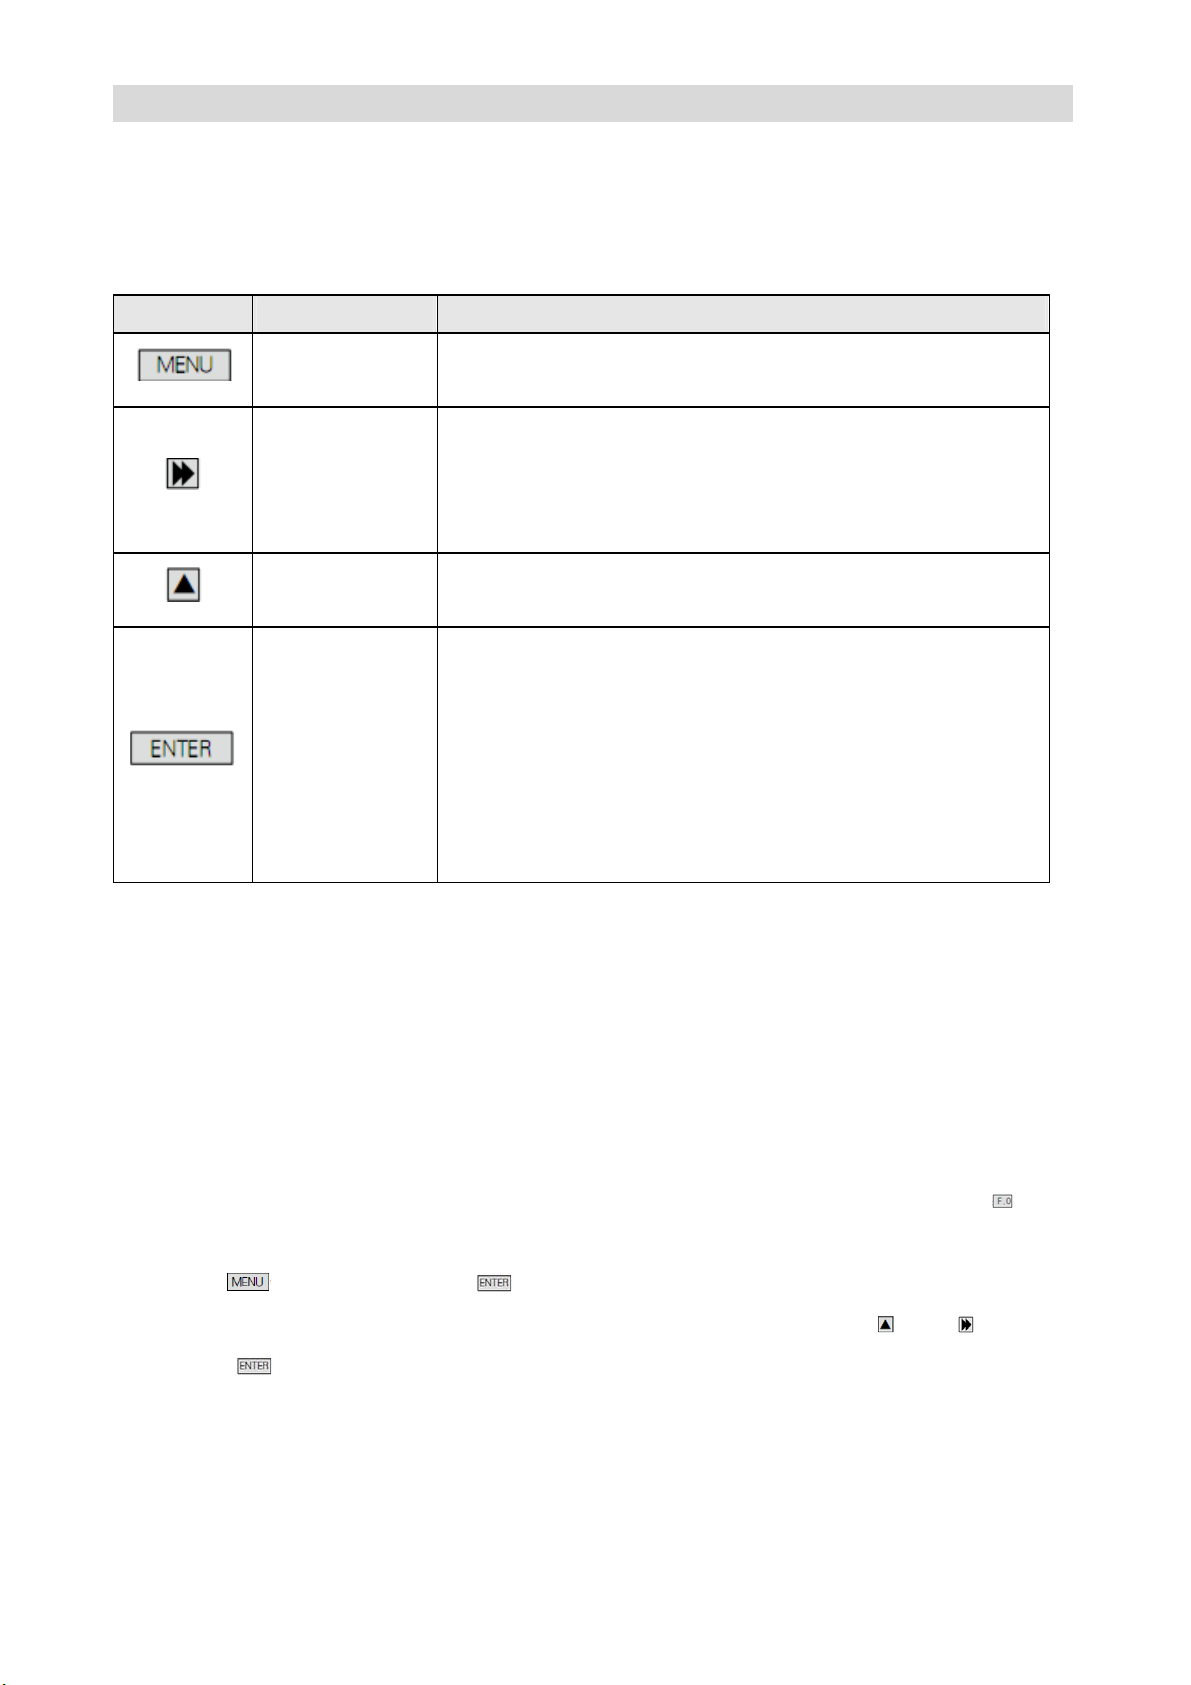
Manipulator key function description
Please see Table 3-2 for function description of the manipulator key
Table 3-2 Manipulator key function
Key Name Function
Menu selection
switching key
Shift key
adjusting key
Confirm / enter key
switching key of each menu item;
It's used to switch data bit of the parameter number when browse
parameter items;
When modifying data in program state, it can be used to modify
the modified bit of the modified data.
Increase menu item, parameter item or modified parameter value
progressively.
Press the key in program state to return to the previous menu.
Enter the next level menu;
Complete selection of the parameter group in1-level menu;
Complete parameter value checking operation in 2-level menu;
Complete modification and storage operation of the parameter
value in 3-level menu;
It's used to reset driver fault when the driver is in fault alarm state.
The operating state of the driver
0.4 ~ 18.5kw driver has four operating states after power-on: standby, operating,
programming and fault alarm. They are described as follows:
Standby state
0.4 ~ 18.5kw driver is in standby state after power-on and before receiving any operating
control order. The default standby state display function code of LED digital tube is . User
may make LED circling switch display U1, U2 and U3 monitoring function parameter groups
by press key. After press key, user may make LED circling switch display
monitoring parameters defined in function parameter group by pressing and key, and
then press key to check /monitor its value.
It will be limited by H P password and functional parameter An00 and An46 when user want
to check / modify the content of parameter groups other than U1, U2 and U3 during
operation. Please see chapter " Function parameter list " for detail.
Operating state
Page 47
GS DRIVER CTB
When 0.4 ~ 18.5kw driver in standby and no-fault state, it will enter operating state after
receiving operating order.
In normal operating state, user may make LED circling switch display U1, U2 and U3
monitoring function parameter groups by press key. After press key, user may
make LED circling switch display monitoring parameters defined in function parameter
group by pressing and key, and then press key to check /monitor its value.
Programming state
For 0.4 ~ 18.5kw driver, user may switch to the state in which function code parameters can
be modified through , , and on the operator panel. The state is programming
state.
Function parameter value is displayed in programming state, and the bit to be modified is
flashing.
Fault alarm state
In the state, 0.4 ~ 18.5kw driver fails and displays the fault code.
LED displays fault code in fault state, and user may conduct fault reset operation through
the operation panel.
Operative mode of the manipulator
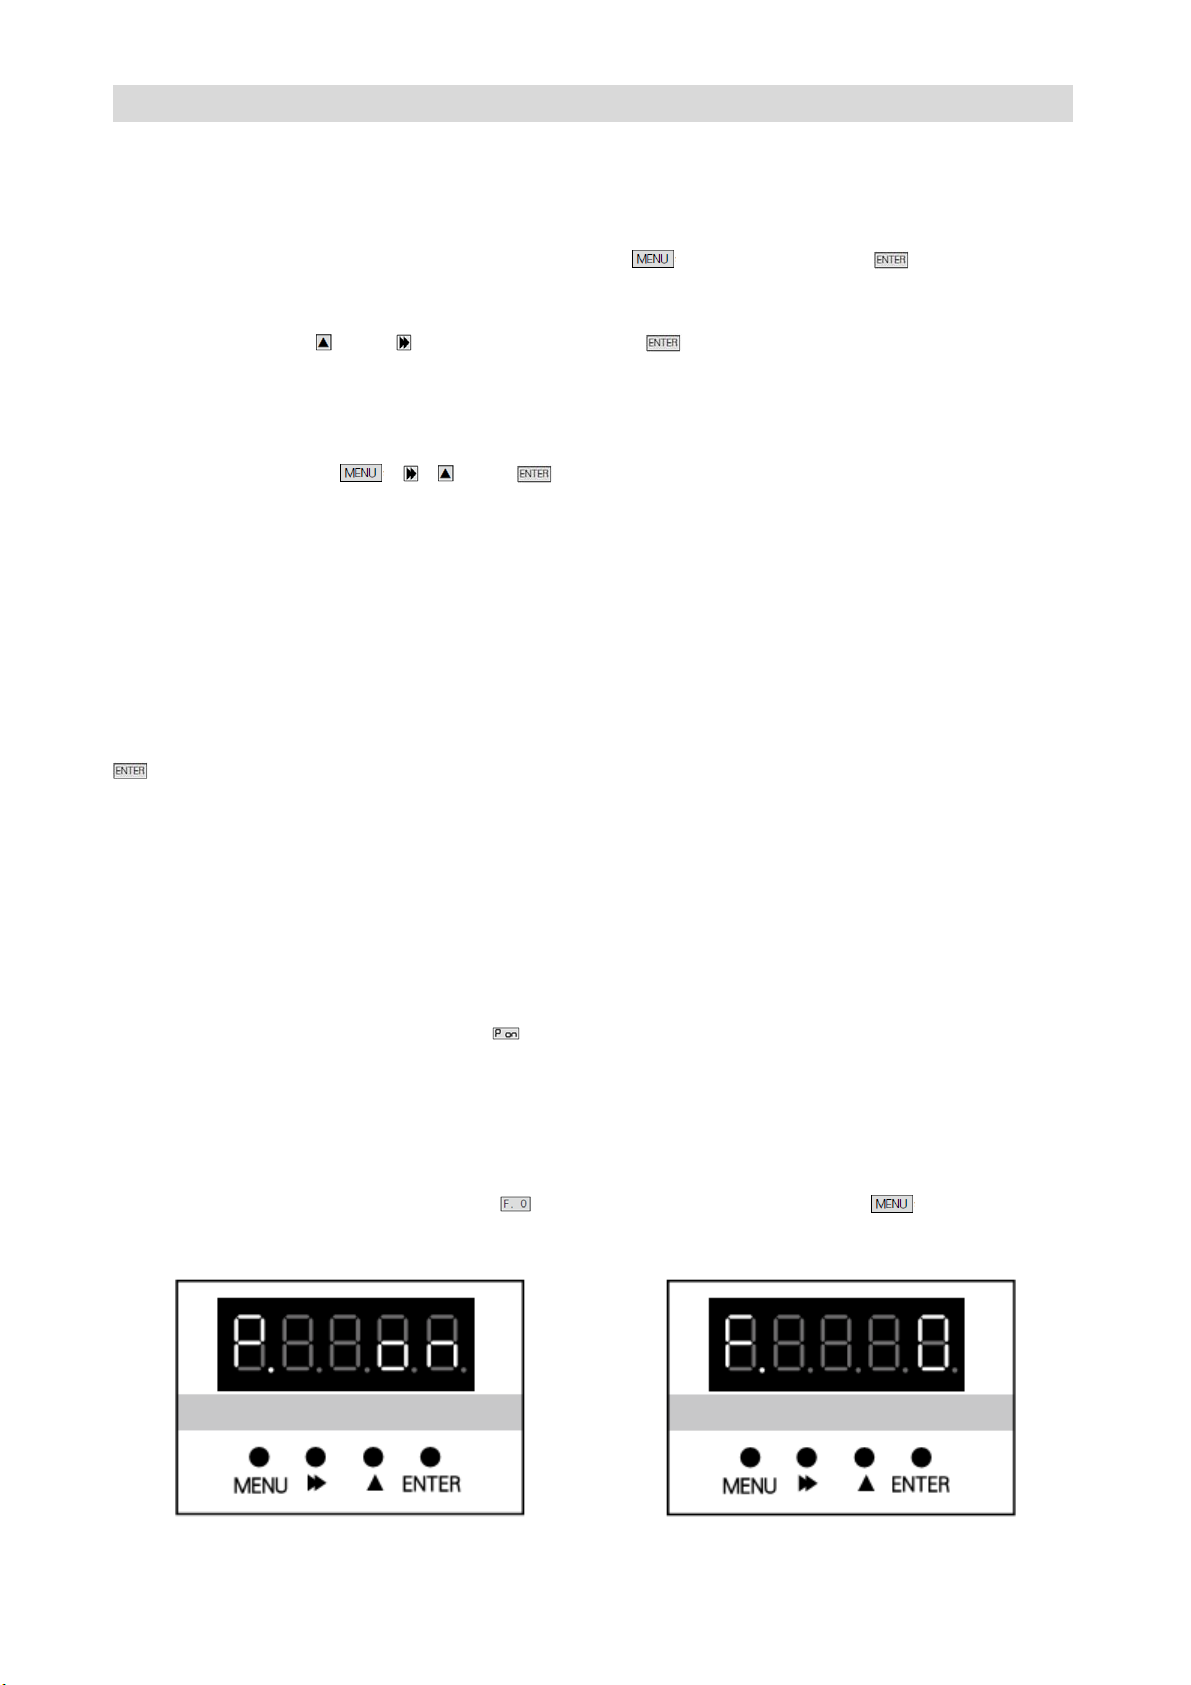
Power-on initialization state:
During power-on of the driver, the manipulator conducts initialization process about 3
seconds. LED digital tube displays
in the process as shown in Figure 3-13.
Standby state:
The state of the manipulator is shown in Figure 3-14 when the driver is in standby state.
The LED digital tube default display . At this point, user may press to enter menu
items, and check or modify parameters.
Figure 3-13 Power-on initialization state
Figure 3-14 Standby state
Page 48
GS DRIVER CTB
Operating state:
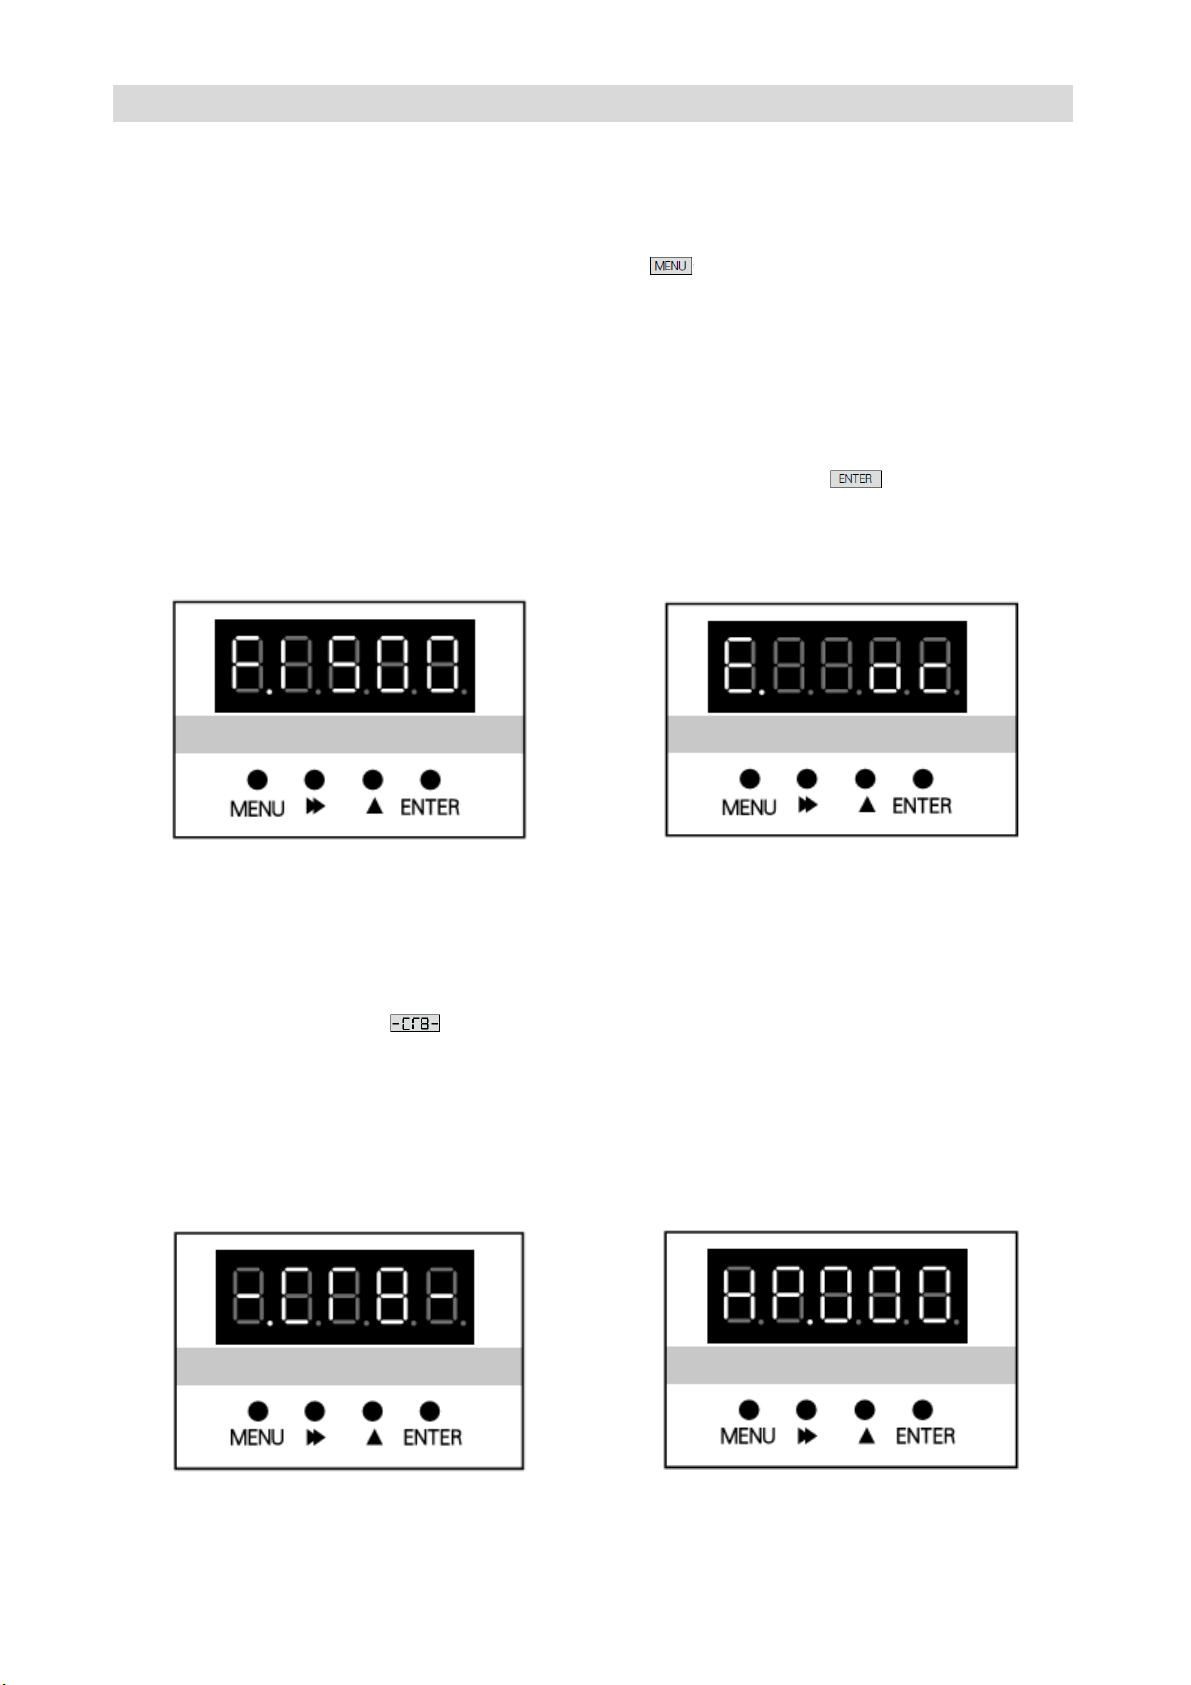
The driver enters operating state after receiving correct operation command in standby
state. As shown in Figure 3-15, the LED digital tube default displays the set speed of the
driver, e.g F. 1500. In this state, user may press to enter menu items, and check or
modify parameters.
Fault alarm state
When fault is detected as the driver is in operating, standby or programming state, the
corresponding fault information will be displayed immediately as shown in Figure 3-16.
When a fault occurs, user may conduct drive reset by pressing . If the fault has
disappeared, it returns to the standby state; if the fault still exists, the fault code will be
displayed again.
Figure 3-15 Operating state
Figure 3-16 Fault alarm state
Parameter transmission state:
Parameter initialization will be carried out within the driver after power-on initialization
every time. The driving returns to normal state after parameter initialization. In this process,
LED digital tube displays
all the time as shown in Figure 3-17.
Password state:
The manipulator will prompt to enter a password as shown in Figure 3-18 when entering
programming state from standby and operating state as An00=1. The password must be
entered correctly in the state before entering the programming state
Figure 3-17 Parameter transmission state
Figure 3-18 Password state
Page 49
GS DRIVER CTB
Use method of the manipulator
The section mainly introduces use of the manipulator, and basic operations of functions.
Parameter setting operation process
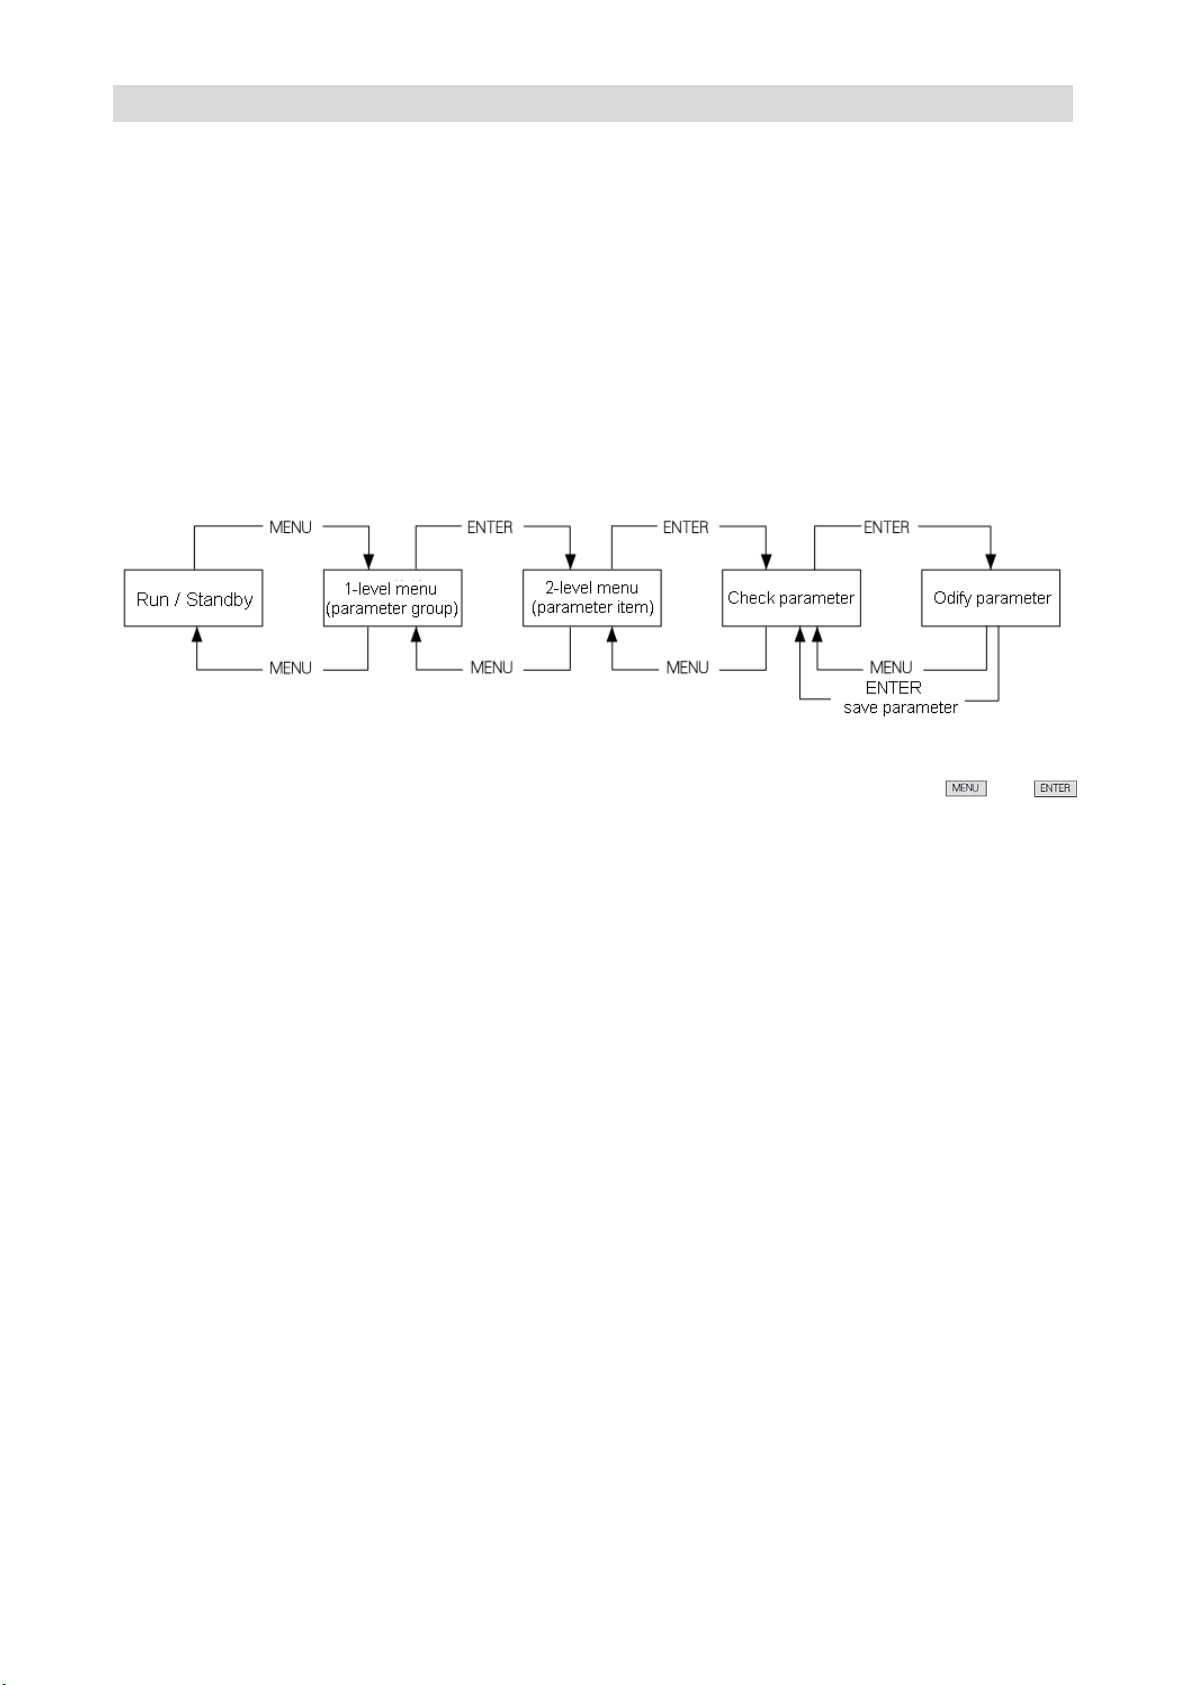
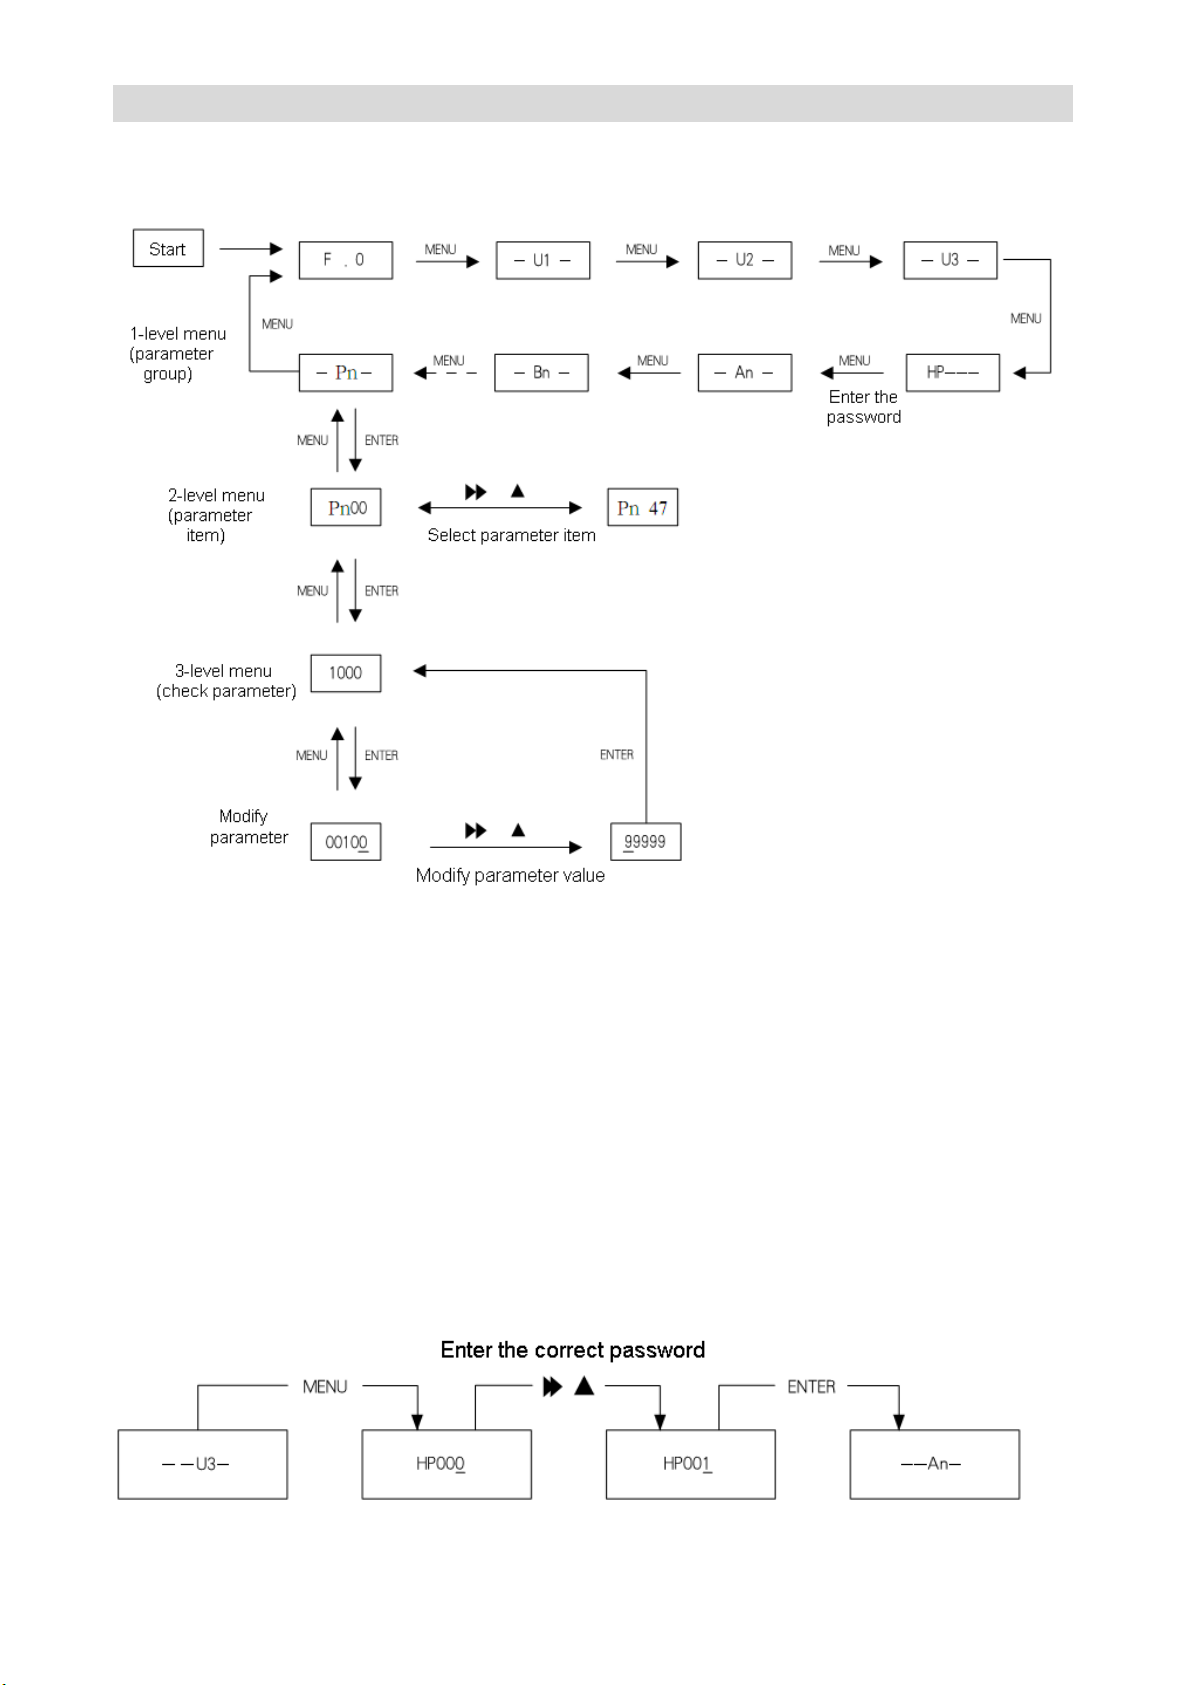
Parameter setting method of manipulator of 0.4 ~ 18.5kw driver adopts three-level menu
structure. Parameter value of menu items can be checked and modified conveniently.
The three-level menu: menu item (1-level menu), parameter tem (2-level menu) and
parameter setting (3-level menu). The operation process is shown in Figure 3-19.
Figure 3-19 3-level menu operation flow chart
During operation in 3-level menu, user may return to 2-level menu by pressing or
(see Figure 3-19 and Figure 3-20). The difference between the two operations: after press
ENTER key, the set parameter value will be saved to the controller, and then return to
2-level menu; it will return to 2-level menu directly without saving the parameter value by
pressing MENU. The detail operational procedures of 3-level menu are shown in Figure
3-20.
Page 50
GS DRIVER CTB
Modify the parameters with the manipulator
The flow chart of modify the parameters with the manipulator is shown in Figure 3-20.
Figure 3-20 3-level menu operation flow chart
★ Description:
Eight menu items are included in 1-level menu: Un menu, An menu, Bn menu, Cn menu,
Dn menu, Fn menu, Pn menu and In menu.
In 2-level menu, each group of parameter includes 48 parameters. Please see parameter
description for specific function.
User password function
To enhance reliability and security of parameter setting, manipulator of 0.4 ~ 18.5kw driver
has user password function. The operating process is shown in Figure 3-21. Please refer to
an22 for modification of user password. The default password is: 00000.
Figure 3-21 User password function operation flow diagram
Page 51
GS DRIVER CTB
Monitor operating state with the manipulator
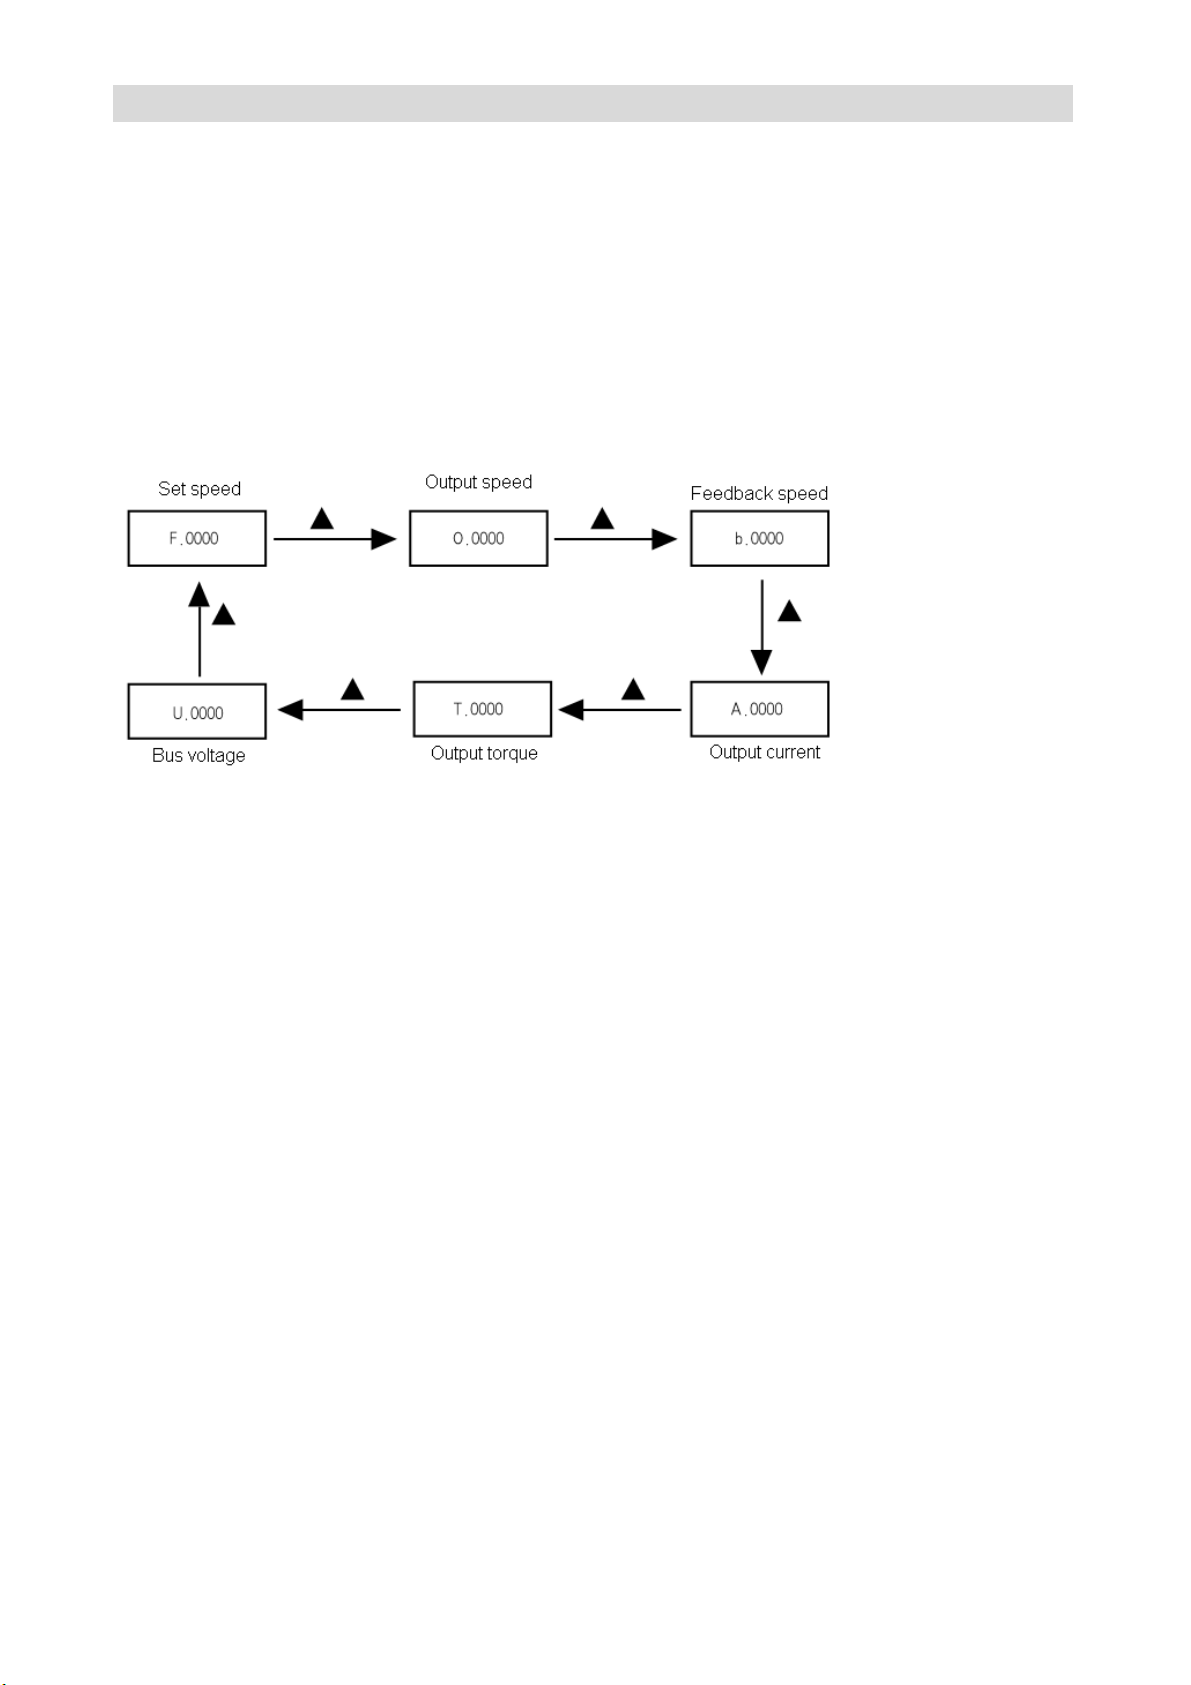
Operation state, interface state and fault information of the driver can be monitored
respectively through U1, U2 and U3 of the manipulator
Operation state monitoring
Operation state monitoring includes set speed F, output speed O, feedback speed b, output
current A, output torque T and DC bus voltage U of the driver. Please see Figure 3-22 for
monitoring method.
Figure 3-22 Driver operation state monitoring flowchart
Interface state monitoring
Interface state includes switching value input terminal u2-2/u2-3, switching value output
terminal u2-4, analog input interface u2-5/u2-6, u2-7/u2-8 and encoder input interface
u2-0/u2-1. The monitoring method is same with monitoring parameter, only needs to select
corresponding parameter in U2.
Please see parameter table of parameter number.
Fault information monitoring
The control panel will display the current fault message code when the driver is in fault state.
The fault record of the driver can be checked through U3. The check operation is same with
monitoring parameter, only needs to select corresponding parameter in U3.
Please see parameter table of parameter number.
22~315k w driver:
Configuration and key functions of the 22~315k w driver manipulator
The chapter defines and describes terms and phrases for operation and state of 22~
315kw driver manipulator, defines the operation methods of the driver and manipulator.
Page 52
GS DRIVER CTB
Please read carefully. It's very helpful for proper use of the 22~315kw driver.
Manipulator
The manipulator is one of the standard equipment of 22~315kw driver. User may carry out
parameter setting, state monitoring, operation control and other operations to the driver
through the manipulator. It's very important to be familiar with function and operation of the
manipulator for proper application of 22~315kw series driver. Please read the manual
carefully before using.
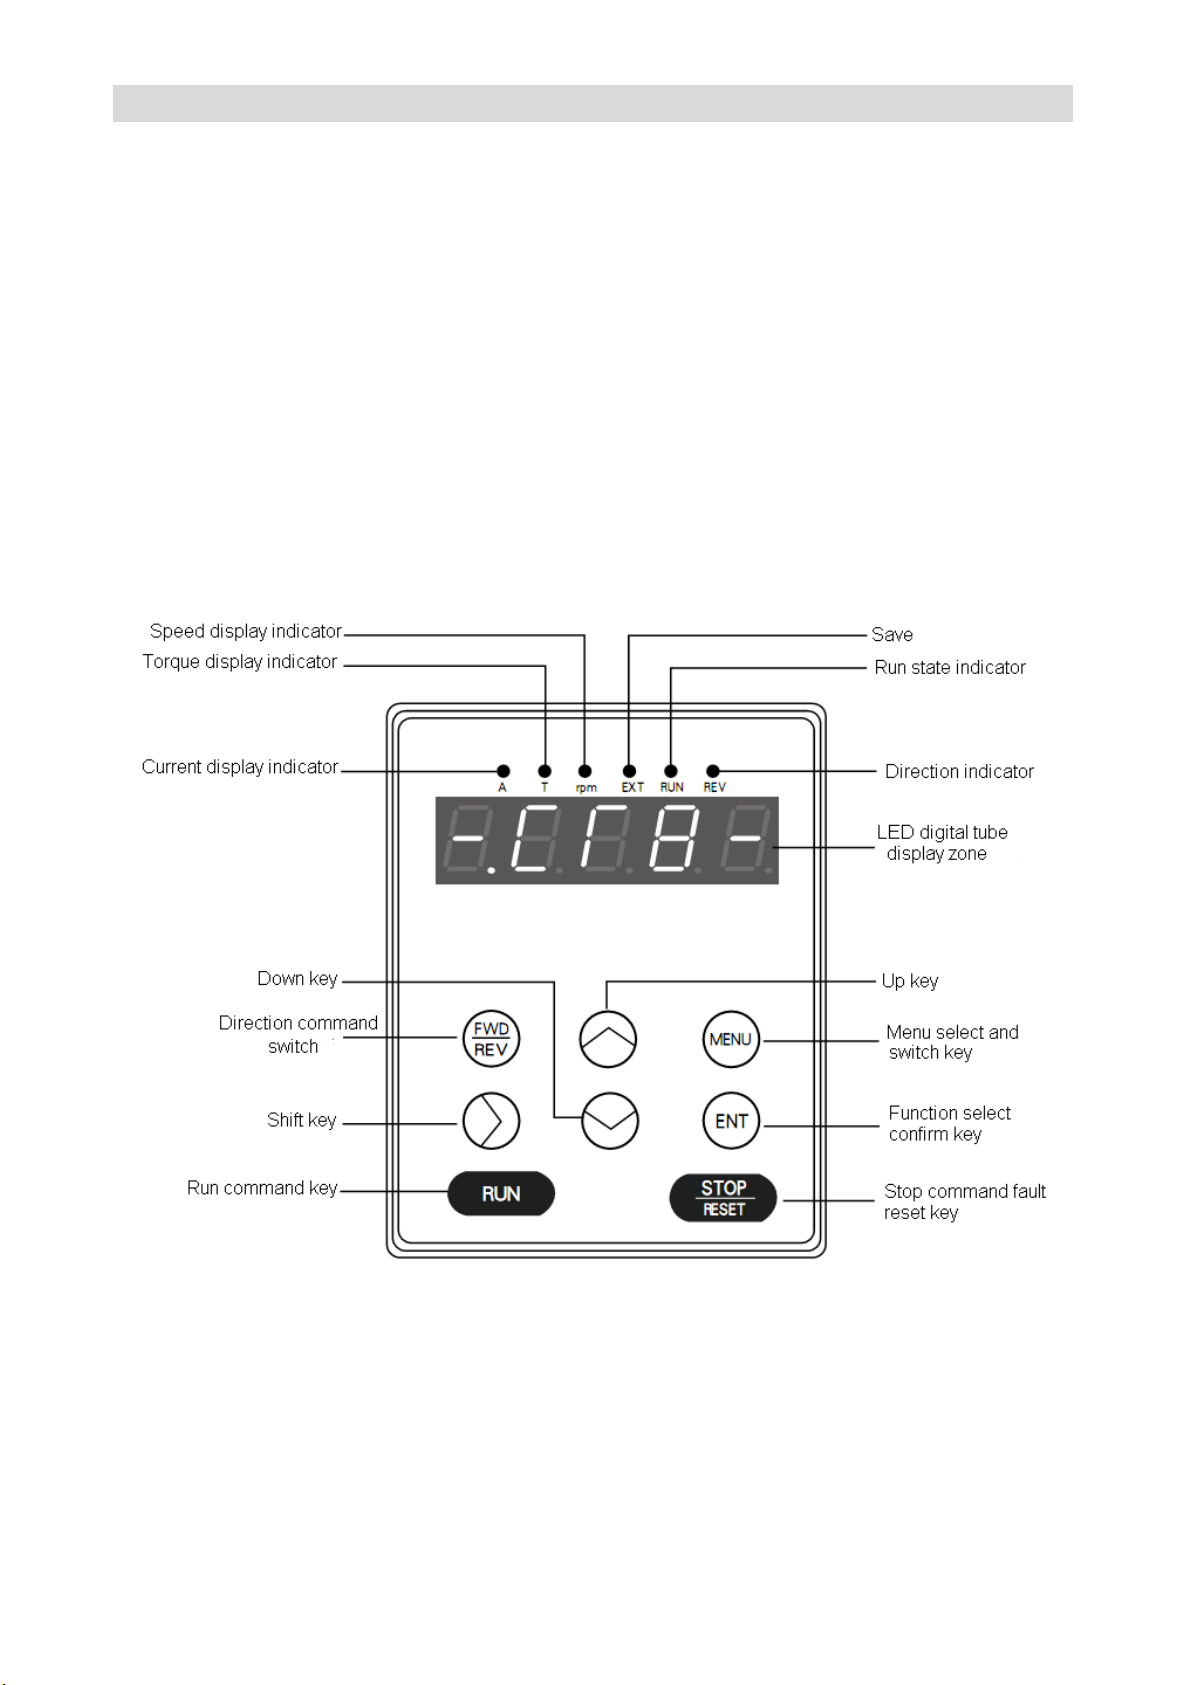
Manipulator appearance diagram
Manipulator of 22~315kw driver is mainly composed of three parts of LED digital tube,
LED indicator and key. The appearance and functional zones are shown in Figure 3-1.
Figure 3-1 Manipulator diagram
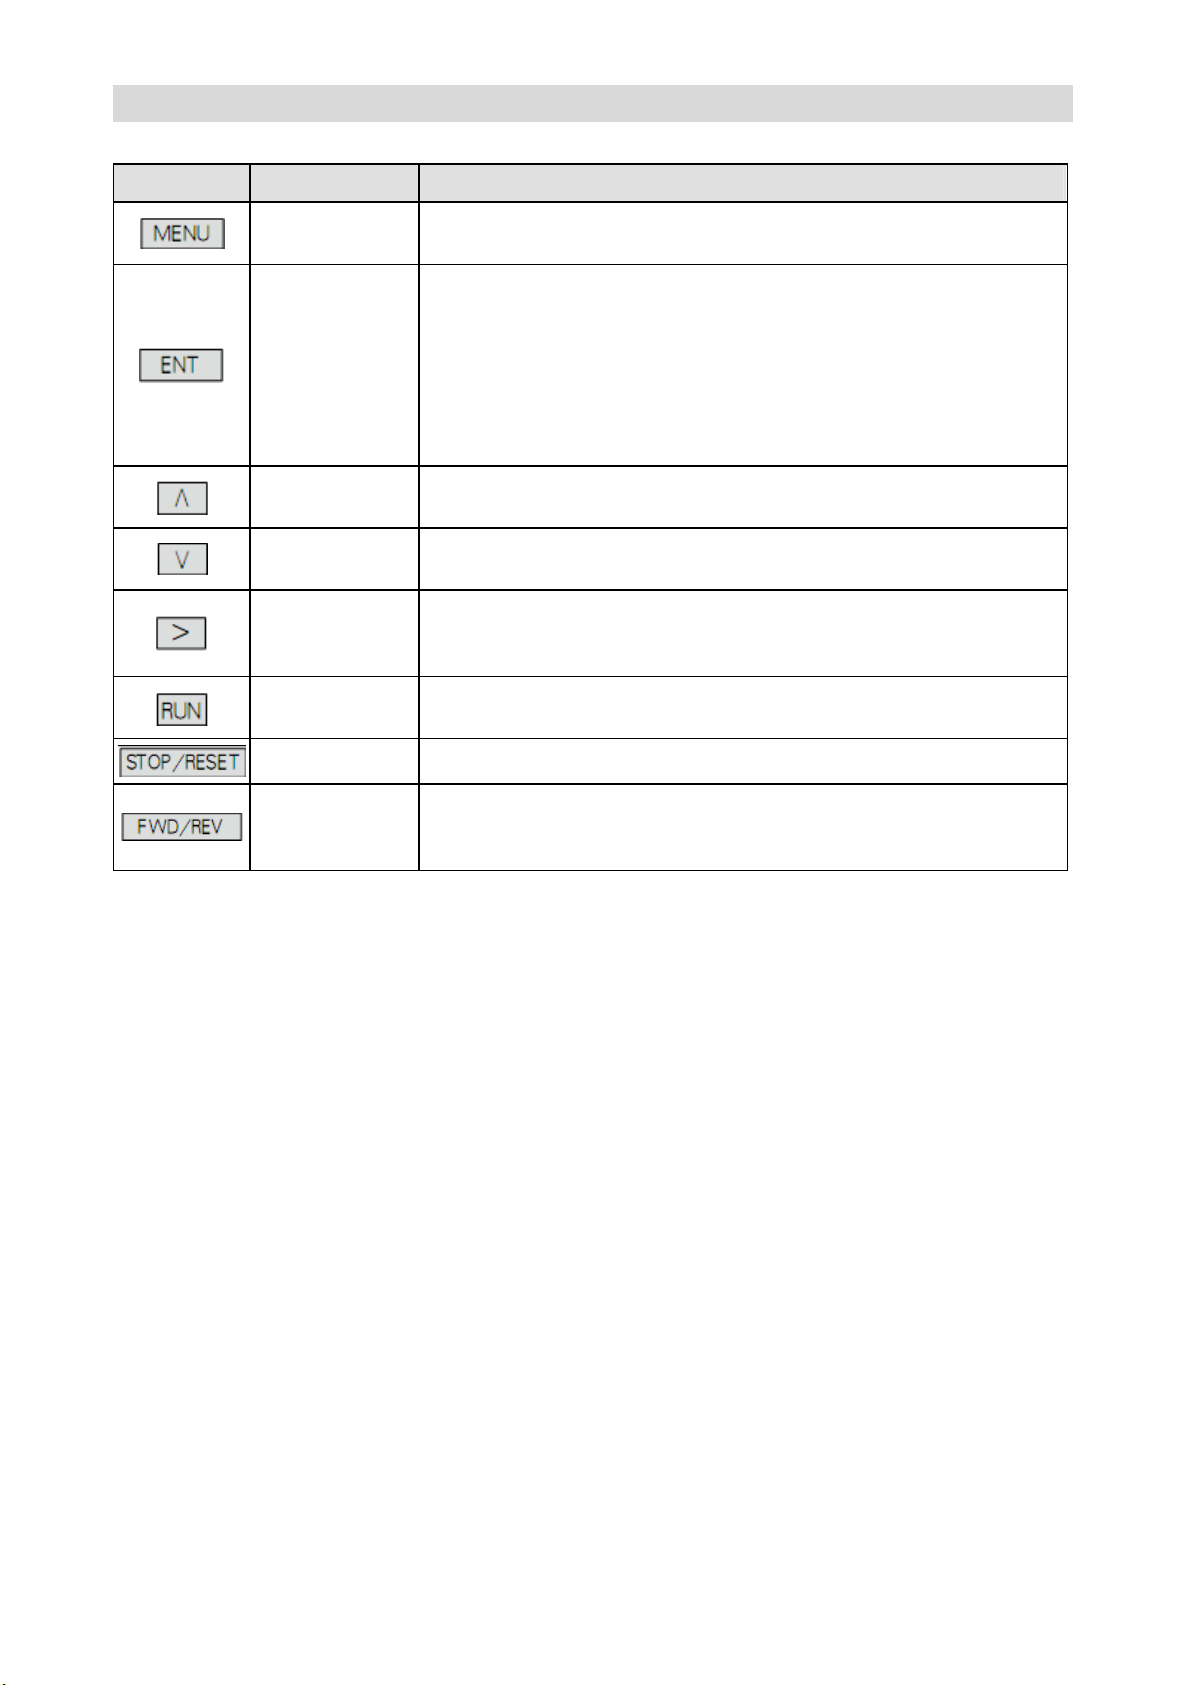
Manipulator key function description
Please see Table 3-1 for function description of the manipulator key
Page 53
GS DRIVER CTB
Table 3-1 Manipulator key function
Key Name Function
Menu select and
switch key
Confirm / enter
up key
down key
Shift key
run command
fault reset key
direction
command switch
key
key
key
switching key of each menu item;
Press the key in program state to return to the previous menu. Enter
the next level menu;
Complete selection of the parameter group in 1-level menu;
Complete parameter value checking operation in 2-level menu;
Complete modification and storage operation of the parameter value
in 3-level menu;
It's used to reset driver fault when the driver is in fault alarm state.
Increase menu item, parameter item or modified parameter value
progressively.
Decrease menu item, parameter item or modified parameter value
progressively.
It's used to switch data bit of the parameter number when browse
parameter items; When modifying data in program state, it can be
used to modify the modified bit of the modified data.
It's used to start the driver in driver control mode;
It's used to reset driver reset when the driver is in fault alarm state.
It's used to select rotation direction of the driver in manipulator
command control mode; under terminal control, the indicator of the
key automatically displays rotation direction of the driver.
Manipulator LED indicator description
There are six LED indicators on the manipulator. They are on or off in various states. The
detail description is as follows:
Current display indicator A:
It has two states of on and off which indicates that the data displayed in the current LED
digital tube display zone is current parameter or not. On means current parameter is
displayed in the LED digital tube display zone; off means that it's not current parameter
displayed in the LED digital tube display zone.
Torque display indicator T:
It has two states of on and off which indicates that the data displayed in the current LED
digital tube display zone is torque parameter or not. On means torque parameter is
displayed in the LED digital tube display zone; off means that it's not torque parameter
displayed in the LED digital tube display zone.
Speed display indicator rpm:
It has two states of on and off which indicates that the data displayed in the current LED
Page 54
GS DRIVER CTB
digital tube display zone is speed parameter or not. On means speed parameter is
displayed in the LED digital tube display zone; off means that it's not speed parameter
displayed in the LED digital tube display zone.
Program running indicator EXT
It has two states of on and off which indicates that the driver program is running or not. On
means the driver program is running; off means the driver program isn't running;
Run state indicator RUN:
It has two states of on and off which indicates the run state of the system under various
operating control orders. On means the driver is in operating state; off means the driver is
shutdown.
Operating direction indicator REV:
It has two states of on and off which indicates the current operating direction of the driver.
On means reverse operation of the driver; off means forward operation of the driver.
The operating state of the driver
22 ~ 315kw driver has four operating states after power-on: standby, operating,
programming and fault alarm. They are described as follows:
Standby state
22~315kw driver is in standby state after power-on and before receiving any operating
control order. The Run state indicator (RUN) on operation panel is off, and the default
tandby state display function code of LED digital tube is . User may make LED circling
switch display U1, U2 and U3 monitoring function parameter groups by press
and press ∧,∨ and > after pressing ENT to make LED circling switch display monitoring
parameters defined in function parameter group, and then press ENT to check /monitor its
value.
It will be limited by H P password and functional parameter An00 and An46 when user want
to check / modify the content of parameter groups other than U1, U2 and U3 during
key,
operation. Please see chapter " Function parameter list " for detail.
Operating state
When 22~315kw driver in standby and no-fault state, it will enter operating state after
receiving operating order. In normal operating state, the Run state indicator (RUN) on
operation panel is on. User may make LED circling switch display U1, U2 and U3
Page 55
GS DRIVER CTB
monitoring function parameter groups by press key. Press ∧,∨ and > after pressing
ENT to make LED circling switch display monitoring parameters defined in function
parameter groups, and then press ENT to check /monitor its value.
Programming state
For 22~315kw driver, user may switch to the state in which function code parameters can
be modified through MENU, ENT, ∧, ∨ and > on the operator panel. The state is
programming state.
Function parameter value is displayed in programming state, and the bit to be modified is
flashing.
Fault alarm state
In the state, 22~315kw driver fails and displays the fault code.
LED displays fault code in fault state, and user may conduct fault reset operation through
ENT and STOP/RESET on the operation panel.
Operative mode of the manipulator
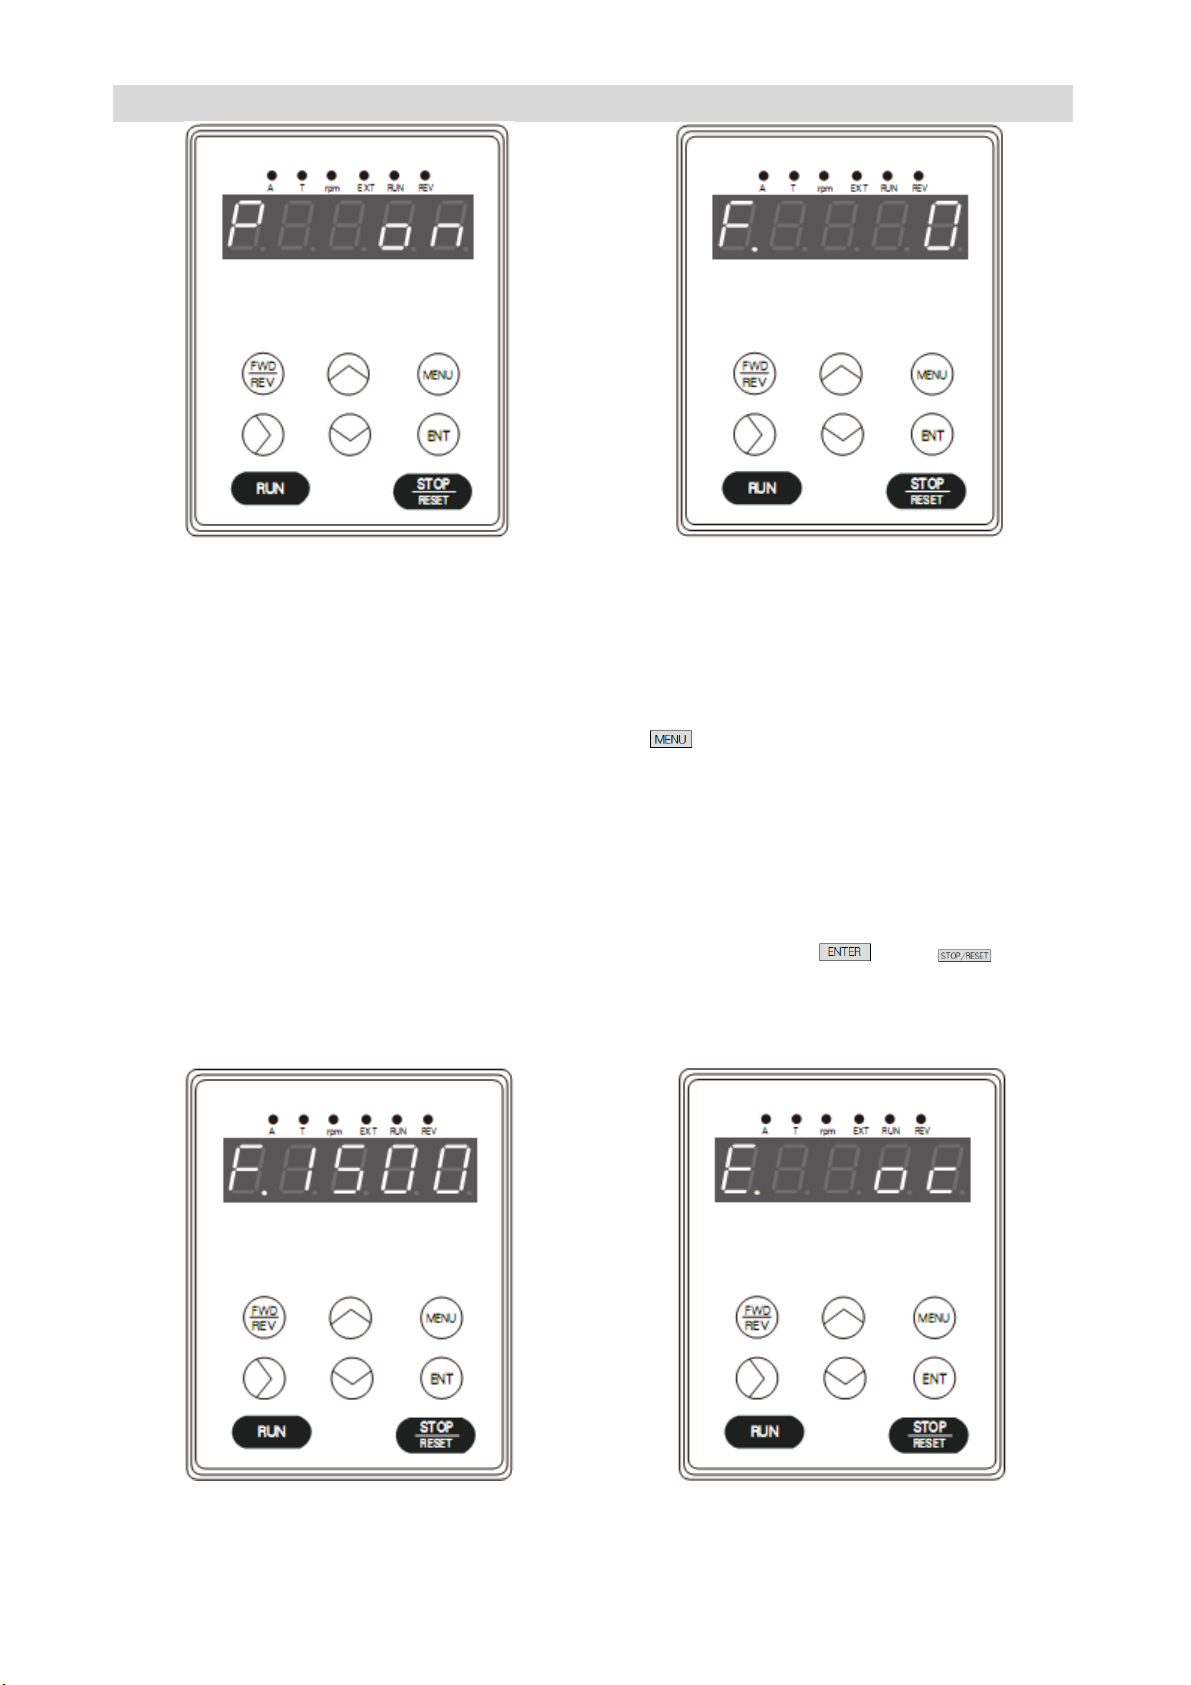
Power-on initialization state:
During power-on of the driver, the manipulator conducts initialization process about 3
seconds. LED digital tube displays in the process as shown in Figure 3-2.
Standby state:
The state of the manipulator is shown in Figure 3-3 when the driver is in standby state. The
LED digital tube default display . At this point, user may press to enter menu items,
and check or modify parameters.
Page 56
GS DRIVER CTB
Figure 3-2 Power-on initialization state
Figure 3-2 Standby state
Operating state:
The driver enters operating state after receiving correct operation command in standby
state. As shown in Figure 3-4, the LED digital tube default displays the set speed of the
driver, e.g F. 1500. In this state, user may press to enter menu items, and check or
modify parameters.
Fault alarm state
When fault is detected as the driver is in operating, standby or programming state, the
corresponding fault information will be displayed immediately as shown in Figure 3-5.
When a fault occurs, user may conduct drive reset by pressing and . If the
fault has disappeared, it returns to the standby state; if the fault still exists, the fault code
will be displayed again.
Figure 3-4 Operating state
Figure 3-5 Fault alarm state
Page 57
GS DRIVER CTB
Parameter transmission state:
Parameter initialization will be carried out within the driver after power-on initialization
every time. The driving returns to normal state after parameter download. In this process,
LED digital tube displays all the time as shown in Figure 3-6.
Password state:
The manipulator will prompt to enter a password as shown in Figure 3-7 when entering
programming state from standby and operating state as An00=1. The password must be
entered correctly in the state before entering the programming state
Figure 3-6 Parameter transmission state
Figure 3-7 Password state
Use method of the manipulator
The section mainly introduces use of the manipulator, and basic operations of functions.
Parameter setting operation process
Parameter setting method of manipulator of 22~315kw driver adopts three-level menu
structure. Parameter value of menu items can be checked and modified conveniently.
The three-level menu: menu item (1-level menu), parameter tem (2-level menu) and
parameter setting (3-level menu). The operation process is shown in Figure 3-8.
Page 58
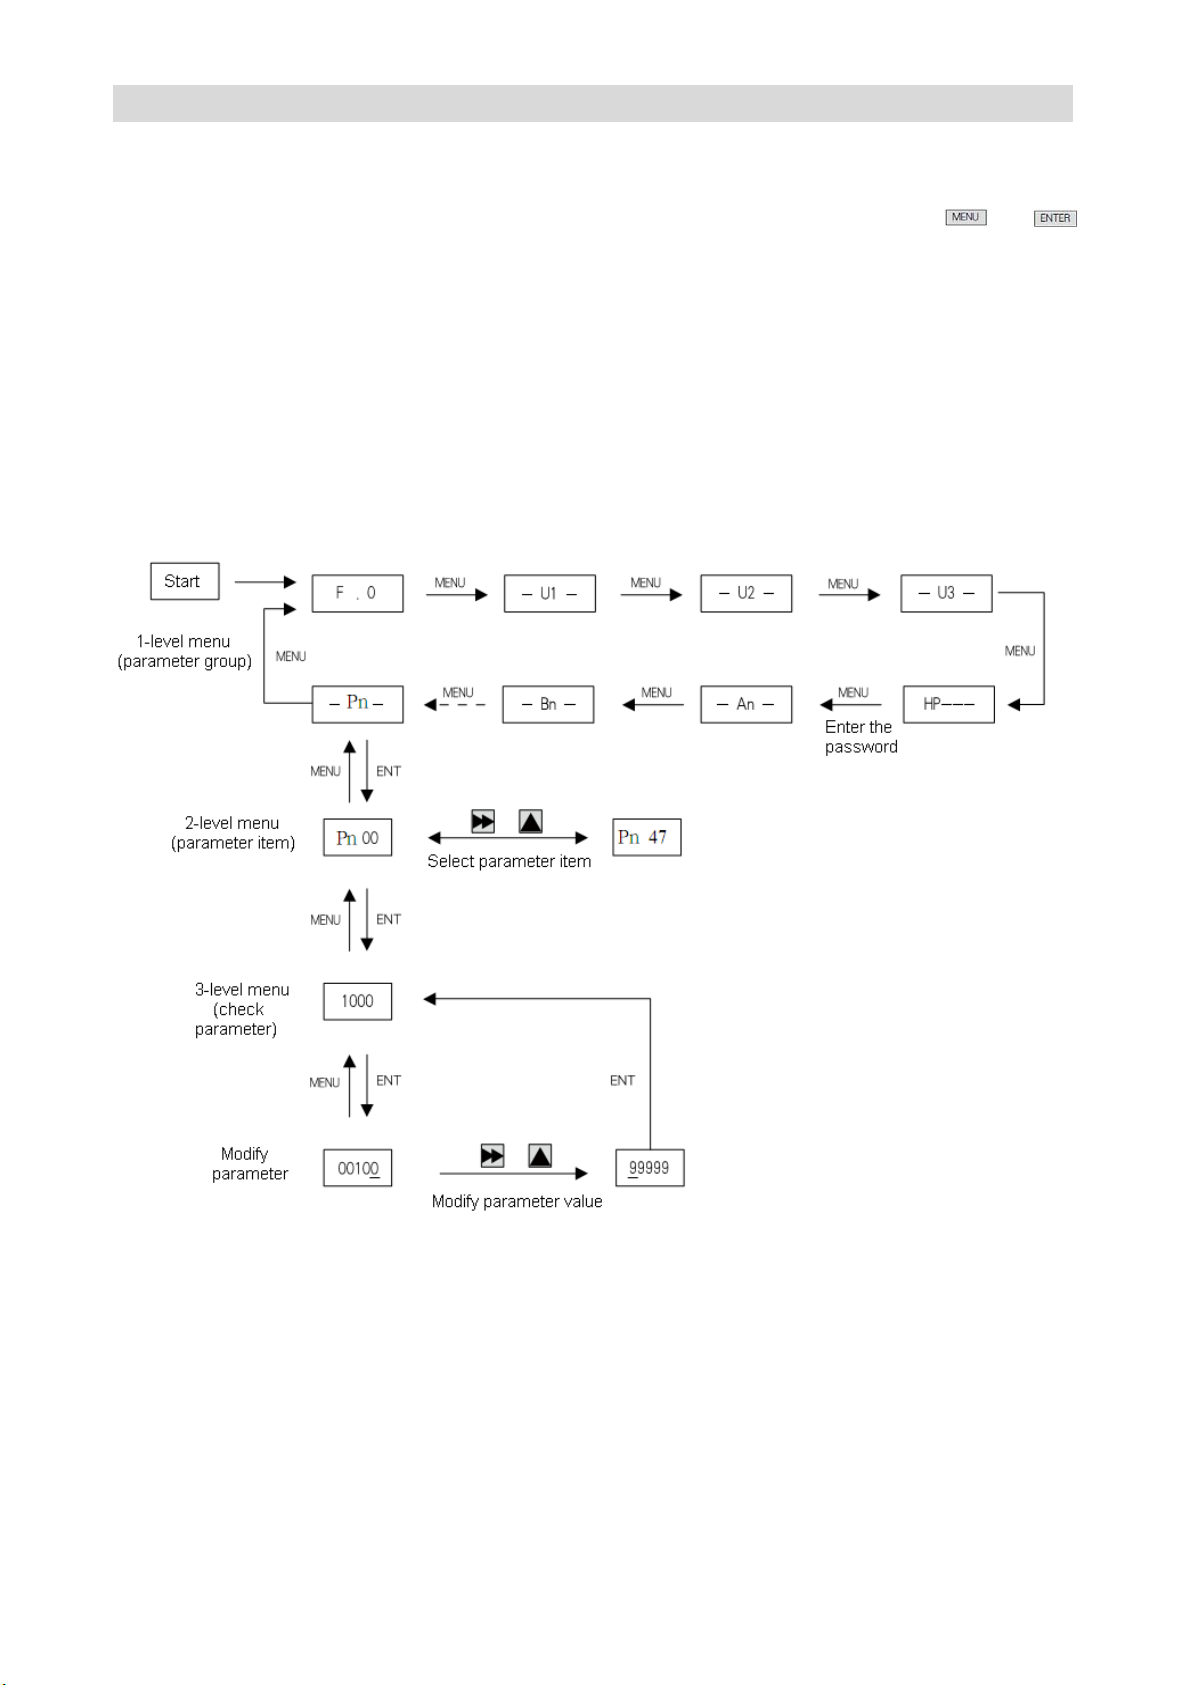
GS DRIVER CTB
Figure 3-8 3-level menu operation flow chart
During operation in 3-level menu, user may return to 2-level menu by pressing or
(see Figure 3-8 and Figure 3-9). The difference between the two operations: after press
ENTER key, the set parameter value will be saved to the controller, and then return to
2-level menu; it will return to 2-level menu directly without saving the parameter value by
pressing MENU. The detail operational procedures of 3-level menu are shown in Figure
3-9.
Modify the parameters with the manipulator
The flow chart of modify the parameters with the manipulator is shown in Figure 3-9.
Figure 3-9 3-level menu operation flow chart
★ Description:
Eight menu items are included in 1-level menu: Un menu, An menu, Bn menu, Cn menu,
Dn menu, Fn menu, Pn menu and In menu.
In 2-level menu, each group of parameter includes 48 parameters. Please see parameter
description for specific function.
Page 59
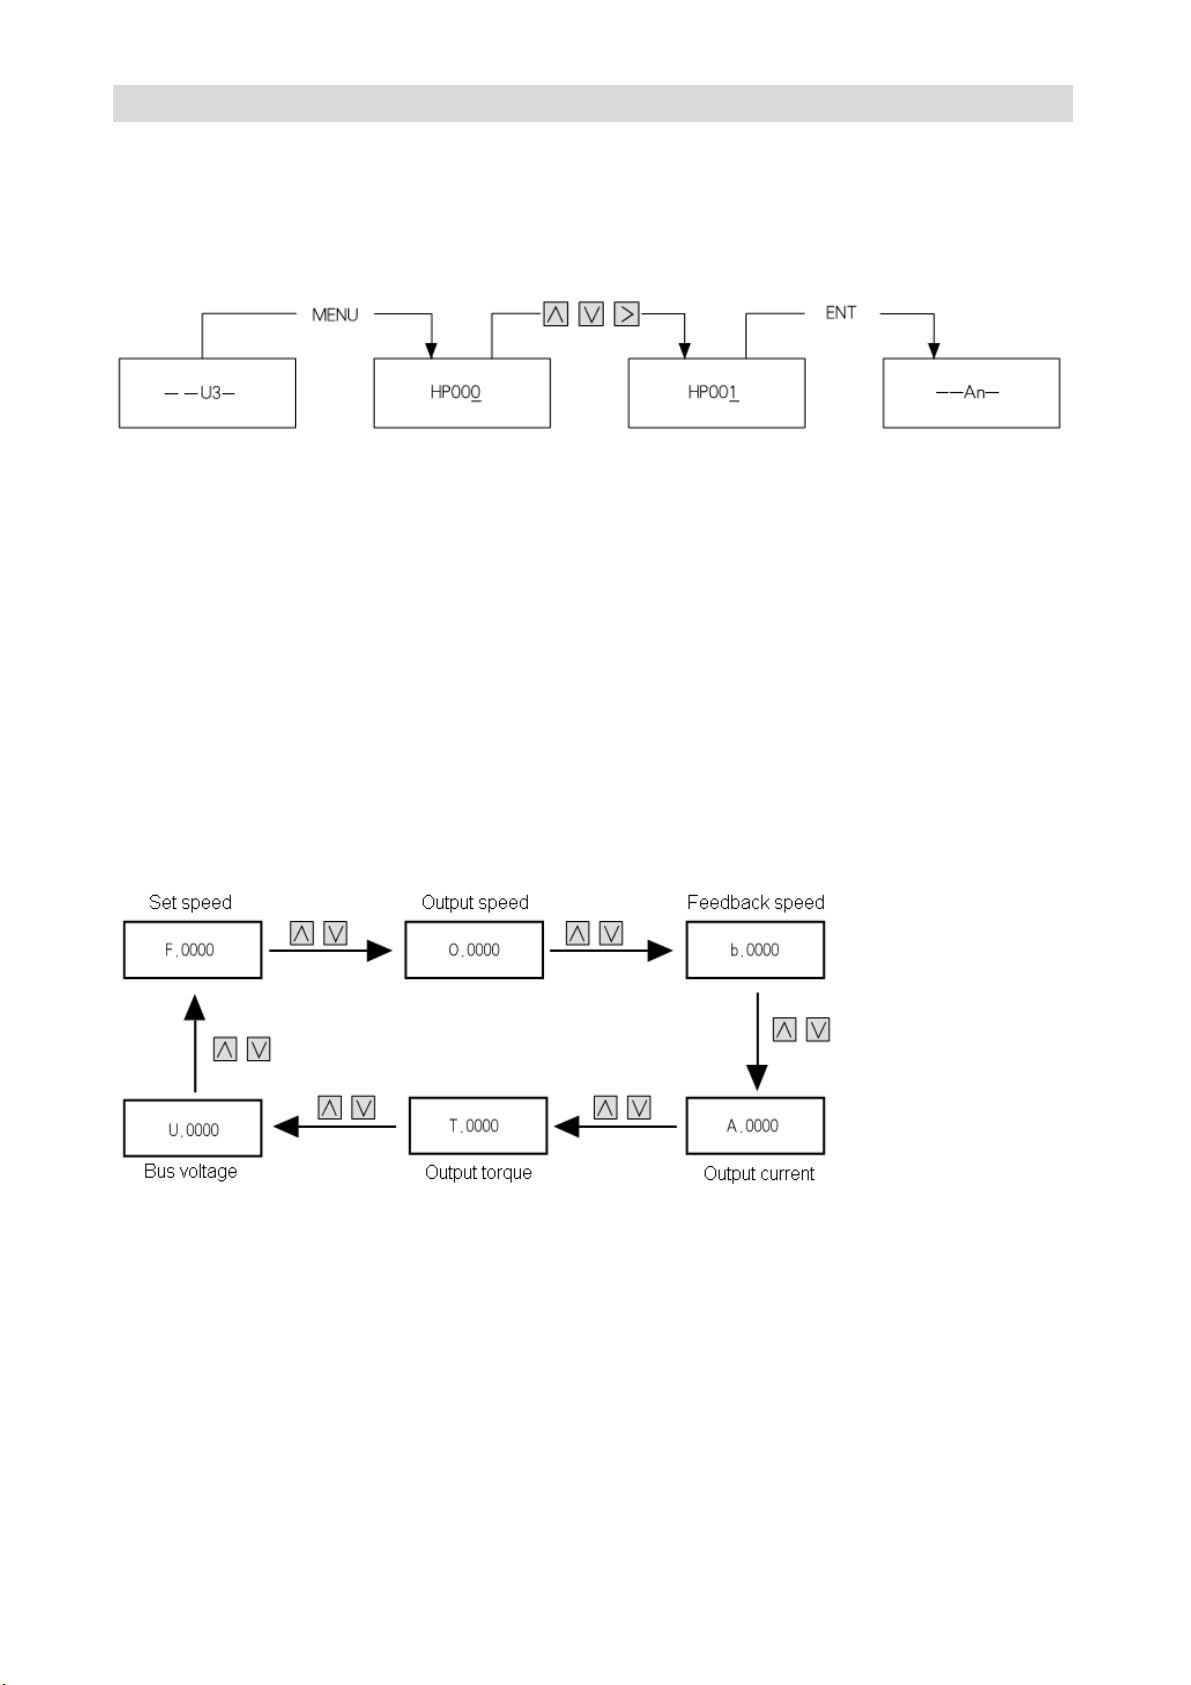
GS DRIVER CTB
User password function
To enhance reliability and security of parameter setting, manipulator of 22~315kw driver
has user password function. The operating process is shown in Figure 3-10. Please refer to
An22 for modification of user password. The default password is: 00000.
Figure 3-10 User password function operation flow diagram
Monitor operating state with the manipulator
Operation state, interface state and fault information of the driver can be monitored
respectively through U1, U2 and U3 of the manipulator
Operation state monitoring
Operation state monitoring includes set speed F, output speed O, feedback speed b, output
current A, output torque T and DC bus voltage U of the driver. Please see Figure 3-11 for
monitoring method.
Figure 3-11 Driver operation state monitoring flowchart
Interface state monitoring
Interface state includes switching value input terminal U2-2/U2-3, switching value output
terminal U2-4, analog input interface U2-5/U2-6, U2-7/U2-8 and encoder input interface
U2-0/U2-1. The monitoring method is same with monitoring parameter, only needs to select
corresponding parameter in U2. Please see parameter table of parameter number.
Page 60
GS DRIVER CTB
Fault information monitoring
The control panel will display the current fault message code when the driver is in fault state.
The fault record of the driver can be checked through U3. The check operation is same with
monitoring parameter, only needs to select corresponding parameter in U3. Please see
parameter table of parameter number.
Page 61
GS DRIVER CTB
Test run
The chapter describes methods and precautions for initial test run of the driver
Basic procedure of test run………………………………..4-2
Confirmation of connection of the main circuit………….4-2
Control circuit wiring confirmation………………………..4-3
Initial power-on of the driver………………………………4-3
Motor and driver parameters confirmation………………4-4
No-load test run…………………………………………….4-4
Loaded test run……………………………………………..4-4
Page 62
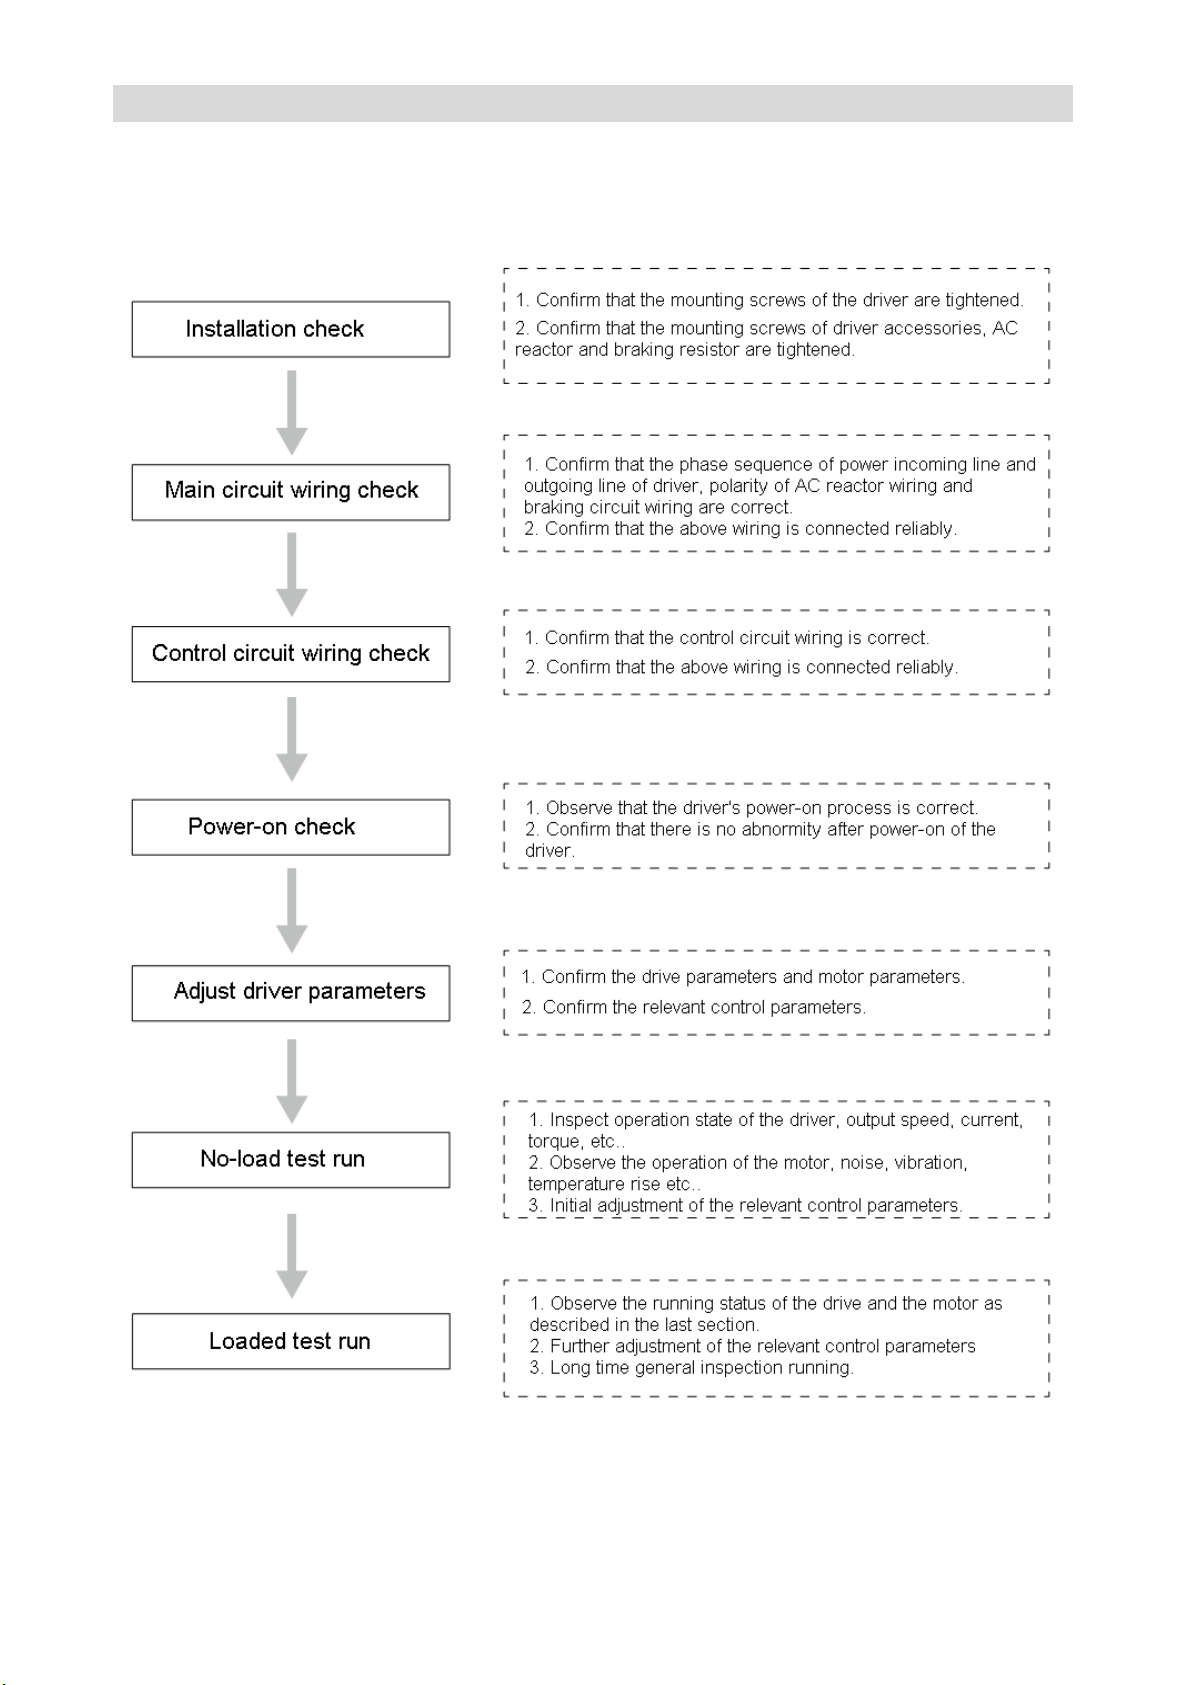
GS DRIVER CTB
Basic procedure of test run
The initial power-on operation of the driver shall be carried out by the following procedures,
otherwise, accident, damage to equipment or other hazards are likely to happen.
Confirmation of the connection of the main circuit
Please confirm the following contents in connection of the main circuit
1. Connect the connecting wire on driver R / S / T to 3-phase power frequency power
Page 63
GS DRIVER CTB
supply. The voltage of the power supply shall meet the requirements of the drive.
2. The driver is equipped with built-in braking unit. The braking resistor is connected to P /
PB. Do not connect any connect wire to N terminal.
3. When the output terminal of the driver is connected to the motor, it shall by ensured that
their phase sequences are same, otherwise, he motor cannot operate normally, and prone
to burn the equipment. If shield cable is used for output cable, the shielding layer at the
ends of the cable shall be connected respectively to ground terminal of the drive and motor.
4. When filtering magnet ring is installed on the output line, it shall be close to the driver
side as possible. The shielding layer and ground line cannot pass through the magnet ting,
and the magnet ting cannot be in contact with the U / V / W terminal.
5.The driver and motor must be well grounded.
6. Confirm all connecting wire are connected reliably.
Control circuit wiring confirmation
Please confirm the following contents for control circuit wiring and jumper
1. Confirm the terminal input state is connected correctly by the design requirements. NPN
mode shall be selected when output signal of the CNC system is 24V; PNP mode shall be
selected when output signal of the CNC system is 0V (by modifying Bn46).
2. It's prohibited to connect the high-voltage line to the control signal.
3. Analog signal input signal connecting line must use shielded cable. The shielded cable
shall be connected to housing of the connector.
4. When use 0 ~ 10V as speed set, confirm that the J2 jumper is plugged, and the j1 jumper
is unpluggd.
5. Cable for motor encoder shall use the standard cable provided by the manufacturer.
6. Connecting wire from encoder output to the CNC system must use shielded twisted pair
cable.
7. Confirm all control signals are connected firmly.
8. ST terminal is driver enabling. The driver cannot start work without input at ST.
Caution
● The wire connection must be inspected carefully before initial power-on of the driver,
otherwise, it's prone to accidents
Initial power-on of the driver
The internal components of the driver may be damaged due to vibration and other reasons
Page 64
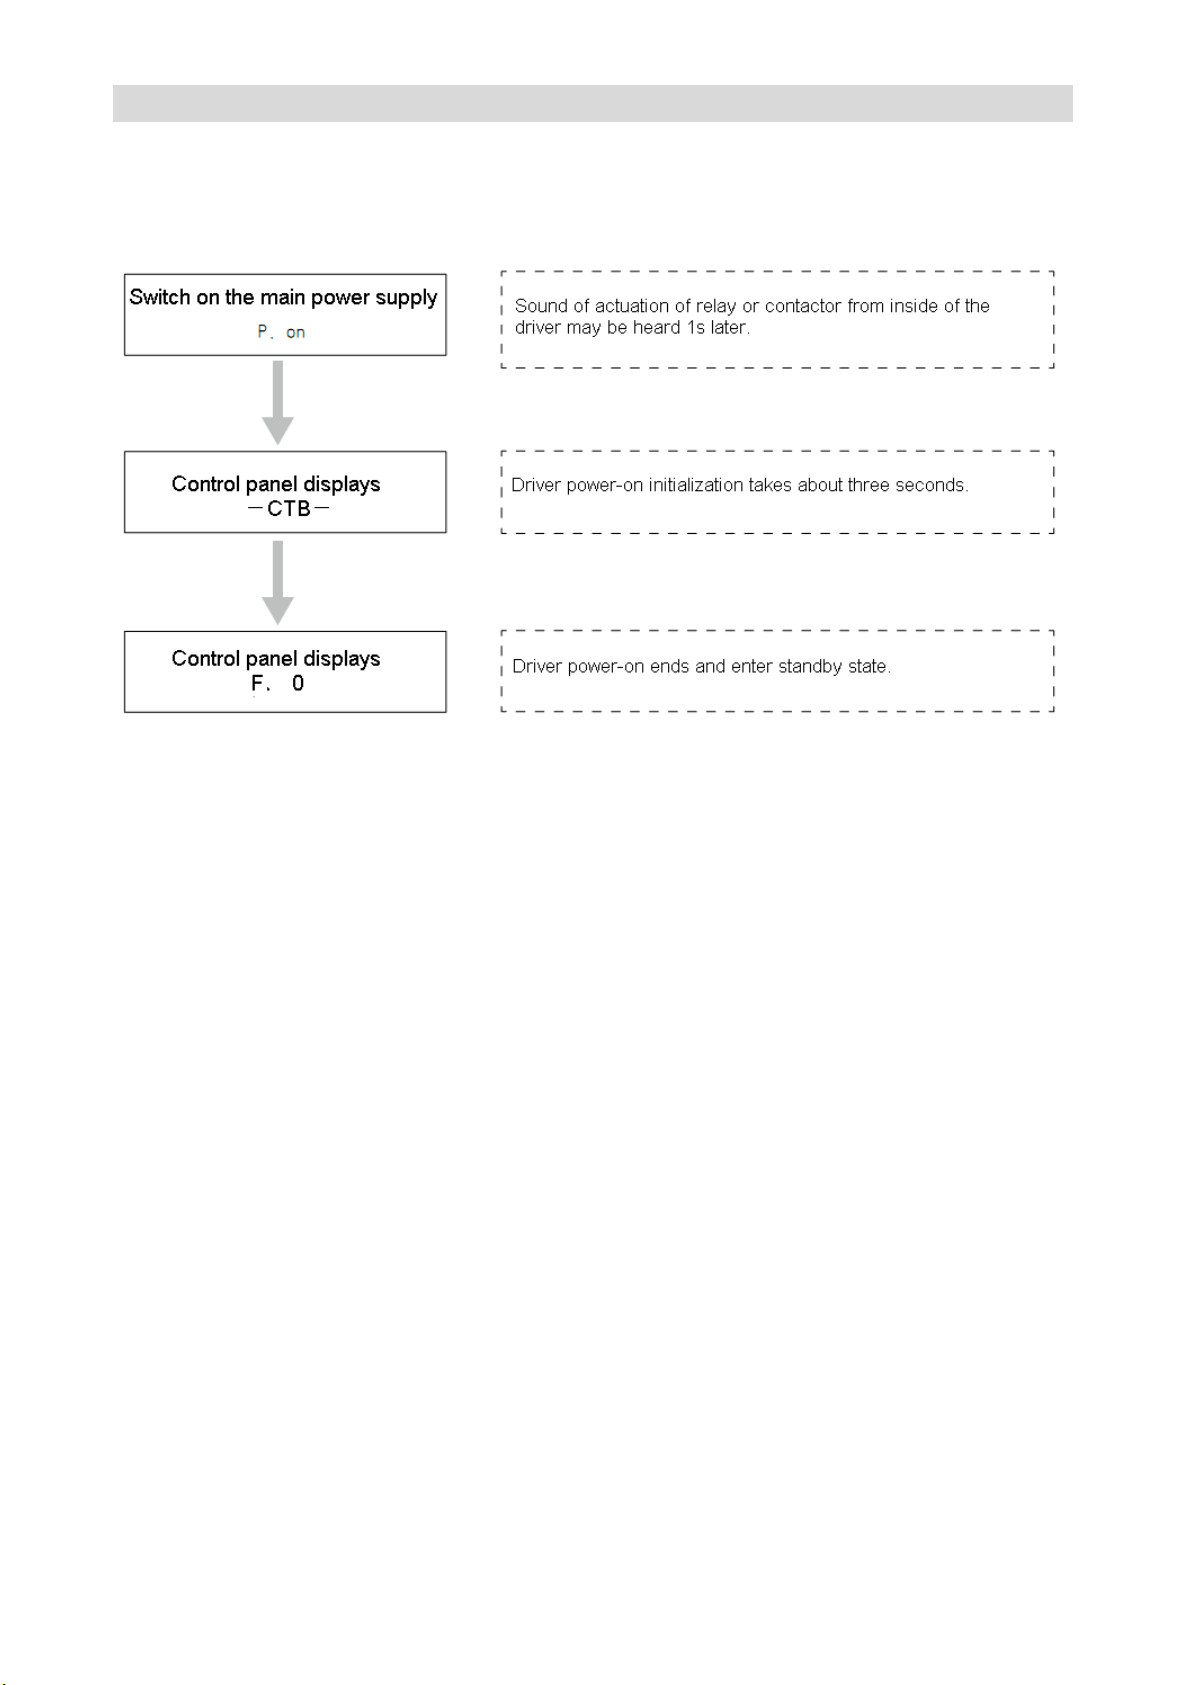
GS DRIVER CTB
during transportation or installation. The power-on process shall be observed carefully in
initial power-on to find problem and treat in a timely manner.
Power-on process of the driver and observation content
Motor and driver parameters confirmation
The default parameters of GS series servo driver shall be basically in conformity with the
practical application. Most of the parameters do not need modification. For initial application,
user shall modify or confirm part of the parameters as required.
Parameters need to be confirmed in test run
● Initialization parameters: An, An-01, An-02, An-03.
● Motor and driver parameters: Dn, Dn00 ~ Dn05, Dn10 Dn20.
● Basic control parameters: Bn, Bn00 ~ Bn47.
● Control relevant parameter-Cn, and modify as needed.
● Relevant system parameter-Sn, and modify as needed.
No-load test run
Test run is carried out with default parameters: analog-10V ~ +10 V speed setting. The
process is as follows:
⑴. Apply 1V voltage to FV-Fc, input enabling signal I0.
Monitor the following data:
◇ The given speed U1-0 is displayed as 150. A few turns deviation is normal and can be
adjusted through parameter Cn
◇ The feedback speed U1-2 is in conformity with the given speed.
Page 65
GS DRIVER CTB
◇ Output current U1-3, deviation below 10% of rated current is normal.
◇ Output torque U1-4, it's normal within 100.
Observe the following phenomenon:
◇ Is the driver fan running?
◇ Is the motor fan running?
◇ Is the motor running smoothly?
◇ Is there abnormal sound during motor operation?
◇ Is surface temperature of the motor normal?
⑵. Disconnect enabling signal
◇Observe the deceleration of the motor is normal or not.
◇Observe heating of braking resistor (braking unit) is serious or not?
⑶. Increase speed continuously, and repeat the first and second step, and monitor
operation of the driver and motor. The equipment must be shutdown immediately for
inspection for any abnormalities, and contact with technical personnel of the manufacturer if
necessary.
Loaded test run
Attention shall be paid to the following contents during loaded test run of the driver:
1. Loading gradually from small to large. Please inspect or contact with the manufacturer
for over loading.
2. Monitor feedback speed, output current and output torque of the driver constantly during
loading; observe motor vibration and noise and temperature rise continuously. The
equipment shall be shutdown timely for any abnormalities.
3. To avoid accident, the motor shall be stopped before adjusting motor parameters. The
parameter regulating quantity shall not be too big.
4. Do not make overload test or destructive test to avoid burning of the driver and motor.
Caution
If the following situations occur, please shut down immediately and inspect, or contact the
manufacturer.
1. Major fluctuation of feedback speed, output current and output torque of the driver, or
reach the limit.
2. The motor operation is abnormal with abnormal vibration and noise.
3. Mechanical equipment abnormalities
Page 66
GS DRIVER CTB
Parameter list
The chapter describes all of parameters of the driver.
Parameter list description………………………………….5-2
Monitor parameter U1………………………………………5-2
Monitor parameter U2………………………………………5-3
Monitor parameter U3……………………………………….5-3
Initialize parameter An………………………………………5-3
Basic control parameter Bn………………………………...5-5
User parameter Cn…………………………………………..5-6
Motor drive parameter Dn…………………………………..5-8
Function parameter Fn……………………….……………..5-9
Function parameter In……………………………………….5-9
Protection parameter Pn……………………………………5-10
System communication parameter Sn……………………5-11
Page 67
GS DRIVER CTB
Parameter list description
Parameter list
Parameter code Item Page
U1 Running state monitoring 5 - 2
U2 Interface state monitoring 5 - 3
U3 Fault record 5 - 3
An Parameter initialization 5 - 3
Bn Basic control parameter 5 -5
Cn User parameter 5 - 6
Dn Motor and driver parameter 5 - 8
Fn Special program function parameter 5- 9
In Special program position function parameter 5 - 9
Pn Protection parameter 5 - 1 0
Sn Communication function parameter 5 - 1 1
1. The contents of the parameter list are described as follows:
Function code: code of parameter group and parameter number;
Name: name of the parameter;
Description:
Setting range: the range of effective setting value of parameter;
Unit: parameter setting unit;
Factory setting: original factory parameter setting;
Change:
"-": indicates changing of setting of the parameter by user is prohibited;
detailed description about function and effective setting value of the
parameter;
parameter changing properties (ie, allow changing or not and change
condition) are as follows:
"○": indicates the setting of the parameter may be changed in shutdown,
operating state of the driver;
"×": indicates the setting of the parameter cannot be changed in
operating state of the driver;
"*": indicates the value of the parameter actually measured value, and
cannot be changed.
Monitoring parameter U1
Operation: press ▲ on the control panel to select the corresponding function code in
operating state to monitor.
Page 68
GS DRIVER CTB
Function
code
F Set speed/frequency
O Output speed/ frequency
b Feedback speed/ frequency
A Driver output current ― A
T
U Driver DC bus voltage
Actual feedback torque of the
Name Description Unit
Speed is displayed with maximum
Speed : rpm
Frequency: Hz
n.m
V
motor
speed<8000rpm;frequency is
displayed with maximum
speed≥10000rpm
Range: -32767〜32767
DC bus voltage =AC power voltage
x1.4
Page 69
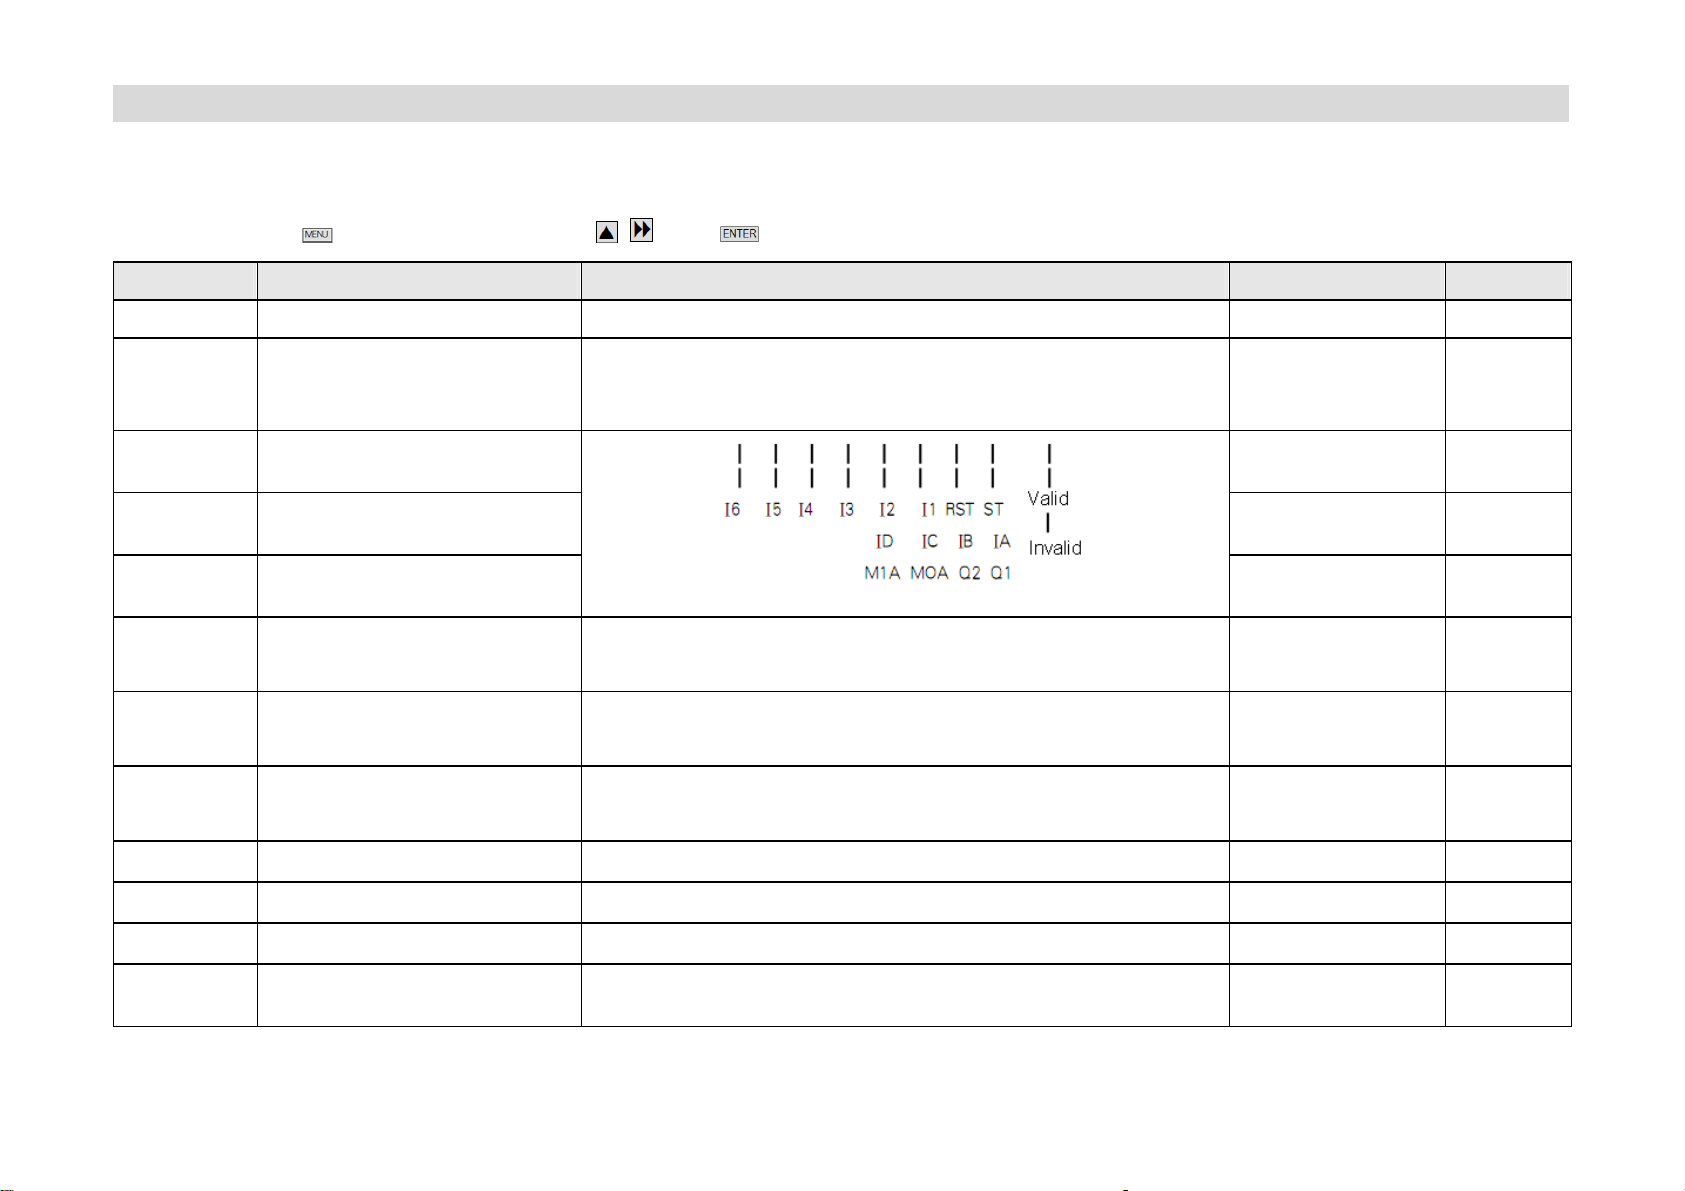
GS DRIVER CTB
Monitoring parameter U2
Operation: press to enter U2, and press , and to select appropriate function code to monitor.
Function code Name Description Setting range Unit
U2-00 Motor encoder count value 4 frequency multiplication counting - PULSE
U2-01
U2-02
U2-03
U2-04
U2-05
U2-06
U2-07
U2-08
U2-09
External input encoder PULSE
input count value
Switching value I1-I6 ST input
state
Internal switching value IA-ID
input state
Switching value output state of
MIA/MOA/Q2-Q1
Analog input FI channel digital
(analog) switching
Analog input FV channel digital
(analog) switching
Analog input FT channel digital
(analog) switching
Multifunction analog input
Module temperature Driver power module temperature display
4 frequency multiplication counting as encoder input.
2 frequency multiplication counting as single PULSE input, 1
frequency multiplication counting as double PULSE input.
Analog quantity 0~+10V
Digital quantity 0~100%
Analog quantity -10~0~+10V
Digital quantity -100%~0~100%
Analog quantity -10~0~+10V
Digital quantity -100%~0~100%
0~100% - V
- PULSE
- ―
-
- ―
- V
- V
- V
- ℃
U2-10
U2-11
Driver temperature Display temperature of inside of the driver
Accurate stop deviation
monitoring
Adjust stop position of the motor
- ℃
0〜9999
PULSE
Page 70
GS DRIVER CTB
Monitor parameter U3
Operation: press to enter U3, and press , and to select appropriate function code to monitor.
Function code Name Description Set range Unit Factory setting Modification
U3-0 Current fault code 一 一 0 *
U3-1 last 1st fault code 一 一 0 *
U3-2 last 2nd fault code 一 一 0 *
U3-3 last 3rd fault code 一 一 0 *
U3-4 last 4th fault code 一 一 0 *
U3-5 last 5th fault code
See fault description for detail (Chapter 7)
一 一 0 *
Initialization parameter An
An parameter list
Function
code
An00
Name Description Set range Unit Factory setting Modification
0: HP password invalid
parameter
password
protection
1: HP password valid
User needs to enter password to enter An, Bn, Cn,
Dn, Fn, In, Pn and Sn.
The initial password is input digital value. The factory
value is 0.
0〜1
- 0 0
Page 71
GS DRIVER CTB
درﮐ بﺎﺧﺗﻧا ﮏﯾ ﺎﯾ رﻔﺻ ار لرﺗﻧﮐ لدﻣ دﯾﺎﺑ 5.5 روﺗوﻣ ﺎﺑ 7.5 وﯾارد ندرﮐ تﺳ یارﺑ
Function code Name Description Set range Unit
Select driver motor control mode
0: induction motor V/F control
An01 Control mode selection
An02 Driver power
An03 Motor model selection See Appendix 1
An04 Software version number Factory software version number 2.00
1: induction motor open loop vector control
2: induction motor servo driver
3: magneto inductor open loop vector control
4: magneto inductor servo driver
1.1Kw:0018 18.5kw:0145 110kw:0168
1.5Kw:0020 22kw:0145 132Kw:0164
2.2Kw:0050 30kw:0146 160kw:0165
3.7kw:0051 37kw:0146 185Kw:0177
5.5kw:0052 45kw:0148 200Kw:0193
7.5kw:0116 55kw:0151 250Kw:0179
11kw:0120 75kw:0150 300Kw:0184
15kw:0121 90Kw:0162
0~4 -
0~32767 - - ×
0~32767 - - ×
Factory
setting
2
Modification
×
An05 Driver encoder selection
An06 Timing time setting Set time that needs timing
An07 Driver power-on time Monitor accumulated power-on time of the driver
An08 Driver operating time Monitor accumulated operating time of the driver
An09
Parameter changing is
allowed
0: encoder 1 port
1: encoder 2 ports
0: Parameter changing is not allowed during operating of
the driver.
1: Parameter changing is allowed during operating of the
0,1 - 0 ×
0~32767
0~65535
0~65535
0.1
h 0
h 0
h 0
-
0 0
×
×
×
Page 72
GS DRIVER CTB
driver
An10 Control program selection
An11
An12
An13
An14
An15
An16
~
An19
Control program version
number
Encoder 1 port interface
type
Encoder 2 ports interface
type
Encoder interface filtering
time
carrier wave frequency
selection
Save - - - ×
0: standard program
1: special program
Control program version number - - J000 ×
0: no encoder card
1: increment TTL encoder card
19: rotary transformer interface card
14: SIN/COS interface card
The other are reserved
0:0.5 3:4 6:32 9:256
1:1 4:8 7:64
2:2 5:16 8:128
0:2 2:8 4:16
1:4 3:12
0.1 - 0 ×
- - - ×
- ms 4 ×
- KHz 2 ×
An20 Timing function valid 0: invalid. 1: valid
An21
An22
Timing function valid
password
Timing function password
setting
Set password to accurate time function. Generally, An20
can only be modified with the value is same with An22
To set initial password of timing function - - - ×
- -
- - - ×
0
Page 73
GS DRIVER CTB
Function code Name Description Set range Unit Factory setting Modification
An23
~
An47
Manufacturer
special
一 一 一 一 ×
Basic control parameter Bn
Bn parameter list
Function code Name Description Set range Unit Factory setting Modification
0: terminal operation
Bn00 Control mode
2: communication operation
1: control panel operation
0.2 一 0 ×
Bn01
Bn02
Bn03
Bn04
Bn05 Motor rotate direction
Bn06
Bn07
Operation command
mode selection
Analog quantity mode
selection
Positioning mode
selection
Accurate stop signal
mode selection
Reverse rotation
forbidden
Machine tool type
0: operation + direction I1: operation signal I2: direction signal
1: forward/reverse I1: forward signal I2: reverse signal
0: bipolar (-10V~+10V) 1: unipolar (0~+10V)
0: motor built-in coded disc
1: spindle encoder
0: accurate stop electrical level valid
1: accurate stop PULSE valid
0: anticlockwise is forward
1: clockwise is forward
0: invalid
1: valid
0: milling 0.1 一 0 ×
0.1
0.1
0.1
0.1
0.1
0.1
一
一
一
一
一
一
0
0
0
0
0
0
×
×
×
×
×
×
Page 74
GS DRIVER CTB
selection 1: turning
Bn08 Speed search in start
Bn09 Stop mode
Bn10 Emergency stop mode
Bn11
Bn12 Save ― 一 - X
Bn13
Bn14
Bn15
Emergency stop
low-voltage inspection
Accurate mode
selection
Accurate stop direction
selection
I1 terminal function
definition
0: invalid
1: valid
0: decelerated stop
1: free stop
0: decelerated stop
1: free stop
0: inspect
1: do not inspect
0: accurate stop according to current speed
1: reverse rotation accurate stop
0: forward rotation accurate stop 1: reverse rotation accurate
stop
0: analog speed control
1: PULSE speed control
0.1
0.1
0.1
0.1
0.1
0.1
0.1
一
一
一
一
一
一
一
0
0
0
0 X
0 X
0 X
0 X
×
×
×
Function code Name Description Set range Unit Factory setting Modification
Bn16 PULSE mode selection
Bn17 High speed mode selection
Bn18 High-accuracy mode
Bn19 I4 terminals function definition
0: direction +PULSE 2:
CW/CCW
1: 90°orthogonal PULSE
0: common mode
1: high speed mode
0: common mode
1: high-accuracy mode
0: analog position control
1: PULSE position control
0.1 一 0
0.1
0.1
0.1
一
一
一
0 X
0 X
0 X
Page 75
GS DRIVER CTB
Bn20 Terminal Q1 output function selection 一 5 X
Bn21 Terminal Q2 output function selection 一 3 X
Bn22 Terminal MOA output function selection 一 7 X
Bn23 Terminal M1A output function selection
Bn24
~
Bn29
Bn30
Bn31
~
Bn44
Bn45
Save function
Multifunction terminal I5 function
selection
Save function
Operation panel control motor rotation
direction selection
0: no output 4: driver fault 1: output
in all time 5: speed
reached 2: driver in operation 6: 0 speed
operation 3: driver ready 7: accurate
stop reached 8: torque alarm point output
0: invalid 3: 0 speed function
1: second accurate stop function 4:
external fault input
2: low-speed function
0: forward 1: reverse 0.1
0〜7
一 一 一
0〜9 一 一
一 一 一
一 4 X
X
X
X
一 一
X
Bn46 I/O electrical level selection 0: PNP 1: NPN 一 一 0 X
Bn47 Control enabling
0: terminal control enabling 1: internal
control enabling
一 一 一
User parameter Cn
Cn parameter list
X
Page 76
GS DRIVER CTB
Function code Name Description Set range Unit Factory setting Modification
Cn00 Save - - - X
Cn01 Analog 0 forward deviation
Cn02 Analog 0 reverse deviation
Cn03 Analog gain
Cn04 Accurate stop offset
Cn05 Second accurate stop offset
Cn06
Cn07 Accurate stop speed
Cn08
Cn09 S curve time in speed control S curve time in speed control 0~5.00 0.01S 0 X
Cn10 Maximum output speed Corresponding speed when input 10V analog 1~8000 rpm 8000 X
Cn11
Accurate stop positioning
speed ring gain
Constant power breaking
point frequency
0 offset compensation in
speed control
To adjust symmetry of analog against 0 point
Actual speed setting=analog sampling value X
Cn03
Set position offset against 0 point during
accurate stop
Set position offset against 0 point during
second point accurate stop
To adjust rigidity during [positioning
Find speed of Z phase PULSE of encoder
during accurate stop
breaking point frequency when motor enters
constant power
When speed command input is 0, offset of
speed command analog can be eliminated
through the parameter to make the motor speed
zero.
0~4096 -
-20~20
0~4 times
encoder line
number
1~32767 -
1~1000
0~10000
-10%~10% - 1 X
0.1 1 X
PULSE 0 X
PULSE 0 X
rpm 300 X
0.01Hz 50.00 X
0 X
500 X
Page 77
GS DRIVER CTB
Function code Name Description Set range Unit Factory setting Modification
Cn12
Cn13
Cn14
Cn15
Cn16
Cn17
Cn18
Spindle acceleration time
during speed control
Speed ring proportional
gain during speed control
Speed ring integration
time constant during
speed control
Speed control 0 speed
proportional gain
Speed control current
loop proportional gain
Speed control current
integration time constant
Analog input filter time
constant
Set acceleration time of spindle acceleration
Set speed ring adjuster proportional gain during
speed control. The gain and rigidity are higher with
greater setting value. Please set the value as small
as possible without vibration generated in the system.
Set speed ring adjuster integration time constant
during speed control. The integration speed and
rigidity are higher with smaller setting value. Please
set the value as small as possible without vibration
generated in the system.
Set speed ring adjuster integration time constant
during speed control. The gain and rigidity are higher
with greater setting value.
Set current loop proportion during speed control
Set current integration time during speed control
Adjust sampling time of analog input port
0〜300
0〜32767 ― 100 X
0〜32767
1〜32767
1〜150
1〜150
0〜6
S 5
― 500 X
― 100 X
― 80 X
ms 80 X
― 0 X
×
Cn19
Cn20
Cn21
Cn22
External encoder line
number
Rigid tapping maximum
speed
Rigid tapping (PULSE
position) control 0 zero
speed proportional gain
Rigid tapping (PULSE
position) acceleration time
Output PULSE number per turn of external encoder
Set the maximum speed of rigid tapping
Set speed ting adjust proportional gain during rigid
tapping (PULSE position) control zero speed. The
gain and rigidity are higher with greater setting value.
Set acceleration time of motor from 0-1000 rpm when
the spindle is in rigid tapping / PULSE position.
0〜32767
0〜3000
1〜32767 -
0〜300
PULSE 1024 X
rpm 1500 X
S 1 X
100 X
Page 78
GS DRIVER CTB
Cn23
Cn24
Cn25
Cn26
Cn27
Cn28
Rigid tapping (PULSE
position) deceleration time
PULSE position control
position ring proportional
gain
Rigid tapping (PULSE
position) speed ring
proportional gain
Rigid tapping (PULSE
position) speed ring
integration time constant
Rigid tapping (PULSE
position) S curve time
Rigid tapping (PULSE
position) current ring
proportional gain
Set deceleration time of motor from 0-1000 rpm when
the spindle is in rigid tapping / PULSE position.
Set position ring adjuster proportional gain during
position control. The gain and rigidity are higher with
greater setting value, and the position lagging is
smaller with same frequency command PULSE,
however, the too small value may cause vibration or
over control.
Set speed ring adjuster proportional gain in speed
control. The gain and rigidity are higher with greater
setting value. Please set the value as big as possible
without vibration generated in the system.
Set speed ring adjuster integration time constant in
speed control. The gain and rigidity are higher with
smaller setting value. Please set the value as small
as possible without vibration generated in the system.
S curve time during rigid tapping (PULSE position)
control
Set current ring proportion during rigid tapping or
PULSE position
0〜300
0〜32767 - 500 X
0〜32767 - 100 X
0〜32767 - 500 X
0—5.00 0.01s 0 X
1〜150 -
S 1 X
80 X
Rigid tapping (PULSE
Cn29
Cn30
Cn31 Output torque limit Set maximum output torque of the driver 0〜1000 0.2% 1000 X
Cn32
Cn33
position) current ring
integration time
Speed control
deceleration time
PULSE command
multiplying power
numerator
PULSE command
multiplying power
Set integration value of current ring during rigid
tapping or PULSE position
Set deceleration time of motor from 0-1000 rpm when
the spindle is in speed control.
Set multiplying power numerator of position
command PULSE (electronic gear)
Set multiplying power denominator of position
command PULSE (electronic gear)
1〜150 -
0〜300
1〜32000 -
1〜32000 -
S 5 X
80 X
1000 X
1000 X
Page 79
GS DRIVER CTB
denominator
Cn34
Cn35
Cn36 0 speed reach range
Cn37
PULSE command
direction reverse
PULSE specified
smoothing filtering time
PULSE position control
precision range
0: normal 1: PULSE command direction reverse
Conduct smoothing filtering to PULSE order. It's
mainly used at field with greater PULSE command
fluctuation.
Set standard of 0 speed reaching. Output 0 speed
signal when output speed is lower than the set value.
Set precision range in positioning
0〜1 -
0〜9 -
0〜32767
0〜32767
0 X
3 X
rpm 100 X
PULSE 2 X
Function code Name Description Set range Unit Factory setting Modification
Cn38 Accurate stop reach range Set positioning precision range 0〜32767 PULSE 2 X
Cn39
Cn40 Swing speed Set swing speed 0〜3000 rpm 300 X
Cn41
Cn42
Torque alarm point threshold
level
Positive direction swing
amplitude
Negative direction swing
amplitude
Set torque limit value
Set the maximum angle of positive swing
Set the maximum angle of negative swing
0〜327
0〜32767
0〜一 32767
Nm
PULSE 300 X
PULSE -300 X
一
X
Cn43
Cn44
Cn45 Swing torque limit
Cn46
Swing control acceleration
time
Swing control deceleration
time
Multifunctional terminal
maximum speed
Set acceleration of motor from 0 to the set
speed during swing control of spindle
Set deceleration of motor from the set speed
to 0 during swing control of spindle
Set the maximum output torque of the driver
during swing
Define the speed setting value of
multifunctional terminal I6
0〜300
0〜300
0〜1000
0〜8000 rpm」
S 1 X
S 1 X
Nm 20 X
400 X
Page 80
GS DRIVER CTB
0: standard acceleration and deceleration curve
(line)
Cn47
Acceleration and deceleration
curve selection
1: acceleration and deceleration curve in fixed
time (without S curve function)
2: acceleration and deceleration curve in fixed
time (with S curve function)
0〜2 - 0 X
Motor driving parameters Dn
Dn parameter list
Function code Name Description Motor mode Set range Unit Factory setting Modification
Dn00 Rated power Set rated output power of motor M,S 0〜110 kw 一 X
Dn01 Rated voltage Set rated output voltage of motor M 0〜460 V 380 X
Dn02 Rated current Set rated output current of motor M,S 0〜300 A 一 X
Dn03 Rated frequency Set rated output frequency of motor M,S 0〜500 Hz 50 X
Dn04 V/F Rated power Set V/F Rated power M 0〜32767 Hz 50 X
Dn05 Rated speed Set rated output speed of motor M,S 0〜15000 rpm 1460 X
Dn06 Rated torque Set no-load current of motor M,S 0〜300 A 一 X
Dn07
Dn08
Dn09
Dn10 Encoder line number
Dn11
Insulation resistance
between conductors
Inductance between
conductors
Inversion
electromotive force
Encoder counting
Set insulation resistance between
conductors of motor
Set reactance between conductors of
motor
1000 rpm inversion electromotive force
EMK
Set physical encoder line number of one
turn of motor
0: forward 1: reverse 0〜1 一 0 X
M,S
M,S
S
M,S
0〜100
一
一 一 一
100〜10000 一
0.01Ω
mH
一
一
1024 X
X
X
X
Page 81
GS DRIVER CTB
direction
Dn12 0 speed current Motor 0 speed current M,S 0〜32767 A 0 X
Dn13 Maximum torque M,S X
0: invalid
1: preset according to control parameters
of motor. Take set steady voltage or
Dn14
Dn15
Motor parameter
self-matching
Encoder position
self-matching
Function code Name Description Motor mode Set range Unit Factory setting Modification
frequency transformer voltage level as
input voltage.
2: preset according to control parameter
of motor. Take DC bus voltage
measured during power-on as input
voltage .
Position self correct of encoder and
motor magnetic pole
0: invalid
1: self correct
2
M,S
S
0〜2 -
0〜1 -
0 X
0 X
Motor parameter self-learning
0: invalid
1:motor induction electromotive
force
2: motor inductance
Dn16 Motor self-learning
Dn17 Weak magnetic speed M - - -
3: motor stator resistance
4: motor rotor resistance
5: reserve
6: reserve
7:automatic self-learning (static)
8: automatic self-learning (rotary)
M.S
0〜15000
rpm 1460 X
Page 82
GS DRIVER CTB
Dn18 Magnetic flow weakening factor M
Dn19 Weak magnetic curve M
Dn20 Driving panel module current - - -
Dn21 Driving panel power - - -
Dn22 DBVD calibration value - - -
Dn23 CVD calibration value - - -
Dn24
Dn25
Dn26 Hall sensor calibration value
Dn27 Test date
Dn28 Checker No.
Dn29 Driving panel model
Dn43~Dn47 Reserve function
Module temperature calibration
value
Radiation fin temperature
calibration value
― ― ―
Reversed by manufacturer
Special program function parameter Fn
Fn parameter list see appendix for detail parameter
Function code Name Description Set range Unit Factory setting Modification
Fn00
~
Fn70
Reserve function ― ― ― 0 X
Special program function parameter In
Page 83
GS DRIVER CTB
In parameter list see appendix for detail parameter
Function code Name Description Set range Unit Factory setting Modification
In00
~
In47
Reserve function ― ― 0 X
Protection parameter Pn
Pn parameter list
Function code Name Description Set range Unit Factory setting Modification
0: valid, real time monitor bus voltage
Pn00
Pn01
Pn02
Pn03
Bus voltage
inspection and alarm
DC bus overvoltage
alarm point
DC bus under voltage
alarm point
Low voltage
inspection and alarm
Report OV1 when it's greater than Pn01. Report UV1 when it's
smaller than Pn02.
1: invalid. Inspect bus voltage but do no alarm
Set alarm value of DC bus overvoltage (bus voltage = AC voltage
x1.4)
Set alarm value of DC bus low voltage (bus voltage = AC voltage
x1.4)
0: valid. Alarm UV1 with signal input
1: invalid
2: report UV when low voltage time is longer than set value of
Pn04.
0.1
0〜800
0〜800
0〜2 -
-
V 800 X
V 400 X
0 X
0 X
Pn04
Pn05
Instant low voltage
alarm time
Motor thermal
protection mode
Valid when Pn03=2
0: N.C. type
1: N.O. type
2: invalid
0〜1000
0.1.2 - 0 X
1ms 10 X
Page 84
GS DRIVER CTB
Pn06
Pn07
Pn08
Pn09
Pn10 Reserve function ― ― 0 X
Pn11 Reserve function ― ― 0 X
Pn12 Reserve function ― ― ― X
Pn13 Reserve function ― ― ― X
Pn14 Radiating fan control
Instant power turn-off
inspection
Instant power-off
inspection time
Power phase lack
inspection
Over current alarm
point
Set alarm time of instant power-off. Output P OFF alarm when
1: prompt alarm, display PL, do not affect operation
Set motor over current alarm value (percent of rated current)
1: run with output of driver. And stop after set time in time-delay
2: operate according to temperature of radiating fin and module:
Operate: radiating fin temperature >4℃ and module
Stop: radiating fin temperature<304℃ and module temperature
0: alarm. Output P OFF signal
1: motor dose not power-on. Do not alarm
2: Alarm after exceeding the alarm time
power-off time exceeds the set value.
0: alarm PL
2: do not alarm
0: run as power-on of driver
Pn 15 after driver stops.
temperature >55℃
<45℃
0〜2 - 0 X
0〜1000
0〜2 - 0 X
0〜200
0〜2 ― 0 X
ms 10 X
% 150 X
Pn15
Pn16 Alarm reset mode
Pn17
Fan time-delay stop
time
Anti-stall function in
acceleration and
Set fan time-delay stop time (valid with Pn14=1)
0: manual reset with ENTER or RET
1: automatic reset. The alarm is reset after alarm signal
disappears
0: invalid, operate by the set acceleration and deceleration time
1: operate by the set acceleration to prevent over-current alarm
0〜100
0.1 ― 0 X
0 — 65535 ― 0 X
S 10 X
Page 85
GS DRIVER CTB
deceleration due to short acceleration time
2: operate by the set deceleration to prevent over-voltage alarm
due to short deceleration time
3: reserve
4: operate by the set deceleration to prevent over-current alarm
due to short deceleration time
~
Pn19
Function code Name Description Set range Unit Factory setting Modification
Pn20
Pn21
Pn22 Encoder 0 bit inspection 0: inspect 1: do no inspect 0.1 一 0 X
Pn23
~
Pn29
Pn30
Pn31 Reserve alarm setting 0: invalid 1: valid 0.1 一 1 X
Pn32 Z phase lack setting 0: invalid 1: valid 0.1 一 1 X
Pn33
Pn34
~
Pn40 Power-off protection function 0: invalid 1: valid 0〜1 一 0 X
Motor encoder under-phase
inspection start frequency
Encoder under-phase
inspection allowed time
Reserve function
Encoder no feedback alarm
setting
Encoder line number error
alarm setting
Reserve function
Motor shaft encoder under-phase inspection start
frequency
Motor shaft encoder under-phase allowed time
0: invalid 1: valid 0.1
0: invalid 1: valid 0.1
0〜255
0〜50
一 一 一
一 一 一
HZ 0 X
65ms 0 X
一
一
1 X
150 X
X
Page 86
GS DRIVER CTB
Pn41
~
Pn47
Power-off protection braking
torque
Reserve function
Set Power-off instant braking torque
0〜100% 一
一 一 一
85 X
X
System communication parameter Sn
Sn parameter list
Function code Name Register No. Description Set range Unit Factory setting Modification
Baud rate:
Sn00 Baud rate 300
Sn01 Data format 301 0: no calibration 1: even parity 2: odd parity 0〜2 一
Sn02 Local host address 302 Station number: 1〜247.0 is broadcast address 0〜247 一 X
Sn03 Answer delay 303 Answer delay 0〜20ms 0〜20 1ms X
Sn04
Accumulation
exceeding time
304
0:300bPS 1:600bPS 2:1200bPS
3:2400bPS 4:4800bPS 5:9600bPS
6:19200bPS 7:38400bPS
Accumulation exceeding time 0.0~60.0s 0〜60
0〜7 一
0.1ms X
Sn05 Command terminal 305
Sn06 Control function 306
bit0:Invalid bit1:i1 bit2:i2 bit3:i3
bit4:i4 bit5:i5 bit6:i6
bit0:Enabling bit1:reset
bit2:run / stop 0: stop 1: run
bit3:forward /reserve 0: forward 1: reserve
bit4:i4
bit5:i5
bit6:i6
Parameter set selection 0-7
0〜8 一
一 一
X
X
Page 87
GS DRIVER CTB
bit7:Reserve
Function code Name Register No. Description Set range Unit Factory setting Modification
bit8:Quick stop and start
bit9:Return to reference point
bit10:Start positioning
bit11:Reserve
Sn06 Control function 306
bit12
bit13
Mode
selection
0: Standard mode
4096: synchronous mode
8192: position mode
12288: reserve
― ―
X
Sn07
Sn08
Sn09
Sn10 Actual speed 310 Display actual speed of motor operation ― ― X
Sn11
Sn12
~
Sn47
Control terminal
state display
Control function
state display
Command speed
setting
Positioning target
value
Reserve ― ― X
307 ― ― X
308 ― ― X
309
311
For speed command setting val during
communication control
For position command setting value during
communication control
― ― X
― ― X
Page 88
GS DRIVER CTB
Set parameter by function
The chapter helps user for parameter setting and debugging by function of use
Spindle control timing sequence state diagram…………….6-2
Motor basic parameters setting……………………………….6-2
Motor operating parameters…………………………………..6-3
Operation panel operation…………………………………….6-3
Analog quantity speed control………………………………..6-3
Acceleration and deceleration control parameters…………6-5
Accurate stop parameters……………………………………..6-6
Rigid tapping…………………………………………………….6-7
PULSE control……………………………………………………..6-8
Swing control……………………………………………………..6-9
Multi-function terminal control………………………………….6-10
Page 89
GS DRIVER CTB
Spindle control timing sequence state diagram
Analog interface control timing sequence
Please control input of GS driver by the following timing sequence when spindle is
controlled by the CNC system through analog interface.
Function
Forward 1 0 0 0 X X Y
Reverse 0 1 0 0 X X Y
Accurate stop
positioning
Rigid tapping /C
shaft
Spindle swing 0 0 0 0 0 1 Y/N
Multifunction 0 0 0 0 1 X Y
Reset X X X X X X X N RET PULSE greater than 100ms
ST I1 I2 I3 I4 I5 I6 FV/FI
X X 1 X X X N Accurate end M10-M1 output
X X 0 1 X X Y Analog or PULSE with bipolarity
Description
I1 may not be connected when
analog is of bipolarity
Swing speed is determined by the
parameters
The functions may be defined
separately
PULSE interface control timing sequence
Standard PULSE interface is provided by GS driver when spindle is controlled by the CNC
system via PULSE interface. GS driver also provides PULSE speed control and PULSE
position synchronization function. Please see the following table for control timing
sequence.
Function
PULSE position
synchronization
PULSE speed
synchronization
I4 I1 Terminal function de Parameter
1 0
0 1
Realize PULSE position synchronization control,
for rigid tapping and C shaft and other functions
Realize PULSE speed synchronization control, for
normal spindle speed control
Description
Bn19=1
Bn 15=1
Note: 1.1 with input signal; 0 no input signal; × regardless of input signal state.
2. Y need analog input; N does not need analog input.
3. If rigid tapping uses PULSE signal, I4 does not need to be controlled, and I4 terminal
function shall be connected.
Page 90
GS DRIVER CTB
4. If speed control uses PULSE signal, analog terminal does not need to be connected, and
I1 or I4 control signal shall be connected.
Motor basic parameter setting
Please set the following parameters correctly before operating according to the motor
Function Name Description Set range Unit
Dn00 Rated power Set rated output power of motor 0〜315 kw ― X
Dn01 Rated voltage
Dn02 Rated current
Dn03
Dn04
Dn05 Rated speed Set rated output speed of motor 0〜15000 rpm 1460 X
Dn06 Rated torque Set no-load current of motor 0〜300 A ― X
Dn10
Rated
frequency
V/F rated
frequency
Encoder line
number
Set rated output voltage of
motor
Set rated output current of
motor
Set rated output frequency of
motor
Set V/F rated frequency
Set encoder line number of
motor
0〜460
0〜300
0〜500
0〜500
100〜10000
V 380 X
A ― X
Hz 50 X
― 50 X
― 1024 X
Factory
setting
Modifica
tion
Motor operating parameter
Cn13 Speed control proportional gain during speed control: speed ring adjuster
proportional gain when setting speed control. The gain and rigidity are higher with greater
setting value. Please set the value as small as possible without vibration generated in the
system.
Cn14 Speed integration time constant during speed control: speed ring adjuster integration
time constant when setting speed control. The interface time is faster and rigidity is higher
with smaller setting value. Please set the value as small as possible without vibration
generated in the system.
Cn15 Speed control 0 speed proportional gain: speed ring adjuster proportional gain when
setting speed 0 speed control. The gain and rigidity are higher with greater setting value.
Speed control current loop proportional gain: current gain in rated speed.
Cn17 Current integration time constant during speed control: current gain in rated speed.
Page 91
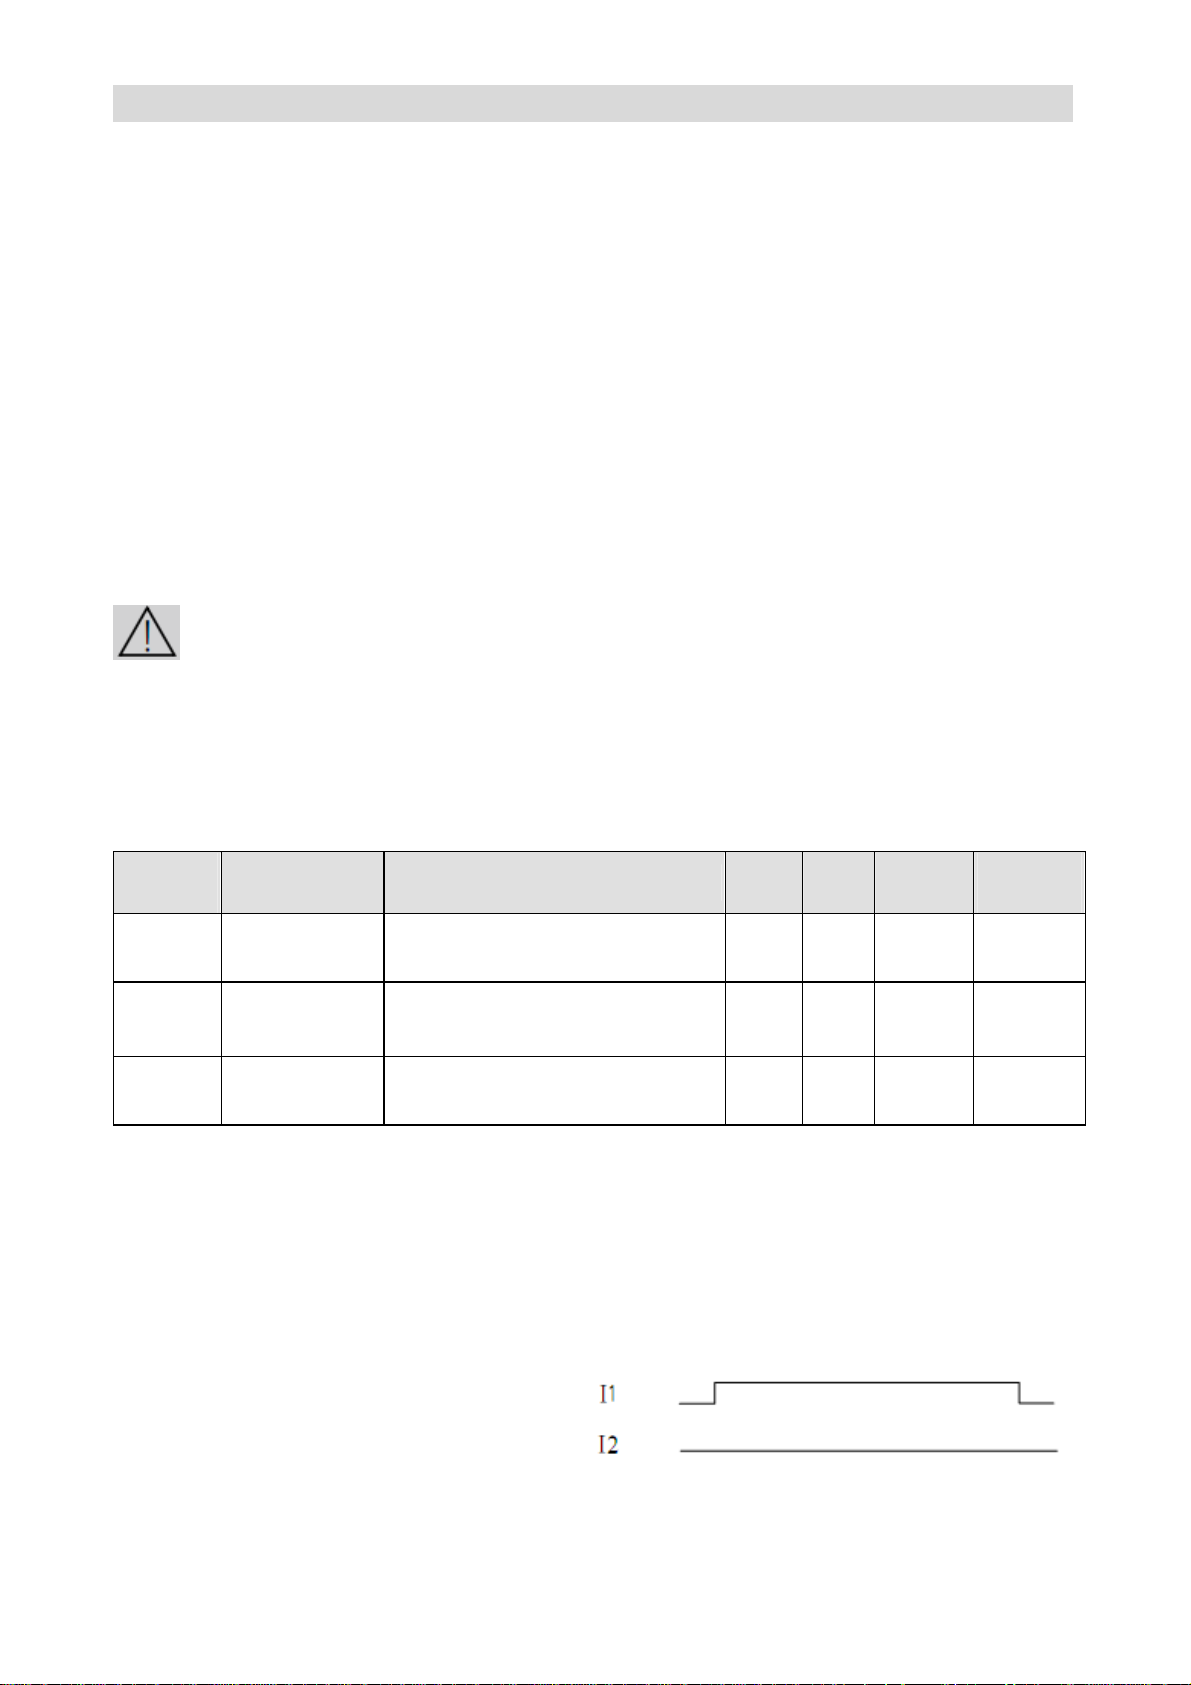
GS DRIVER CTB
Operation panel operation
The method of operation is as follows:
◇ Modify the parameter, make Bn00 = 1 and confirm.
◇ Press RUN on the panel to make driver power-on.
◇In F 0000 menu, press ENT on the panel to enter data input state, press ∧, >> on the
panel to enter the required speed, and press ENT or >> to start the motor.
◇ Press STOP or >> to make motor decelerate and stop.
The 3rd step may be repeated at any time during operating of the motor to change
operating speed of the motor. User may change motor operating direction during operating
through FWD/REV direction command on the panel or modify parameter Bn45.
Caution Operation panel operation is a simple operation mode, and generally used
for test. It's recommended that the motor speed shall not set too high for operation panel
operation.
Analog speed control
Function
code
Bn01
Bn02
Bn05
Name Description
Operating
command mode
Analog mode
selection
Motor operating
direction
1: unipolarity(4~20mA,0~+10V)
0: enabling + direction
1: forward / reverse
0: bipolarity(-10V~+10V)
0: anticlockwise for forward
1: clockwise for forward
When setting Bn01 and Bn02, they shall be selected according to control logic and analog
output mode of the CNC system. The timing sequence is as shown below:
Set
range
0.1
0.1 一 0 X
0.1
Unit
一
一
Factory
setting
0 X
0 X
Modificatio
n
Bn01 = 0, Bn02 = 0:
Forward timing sequence diagram
Page 92
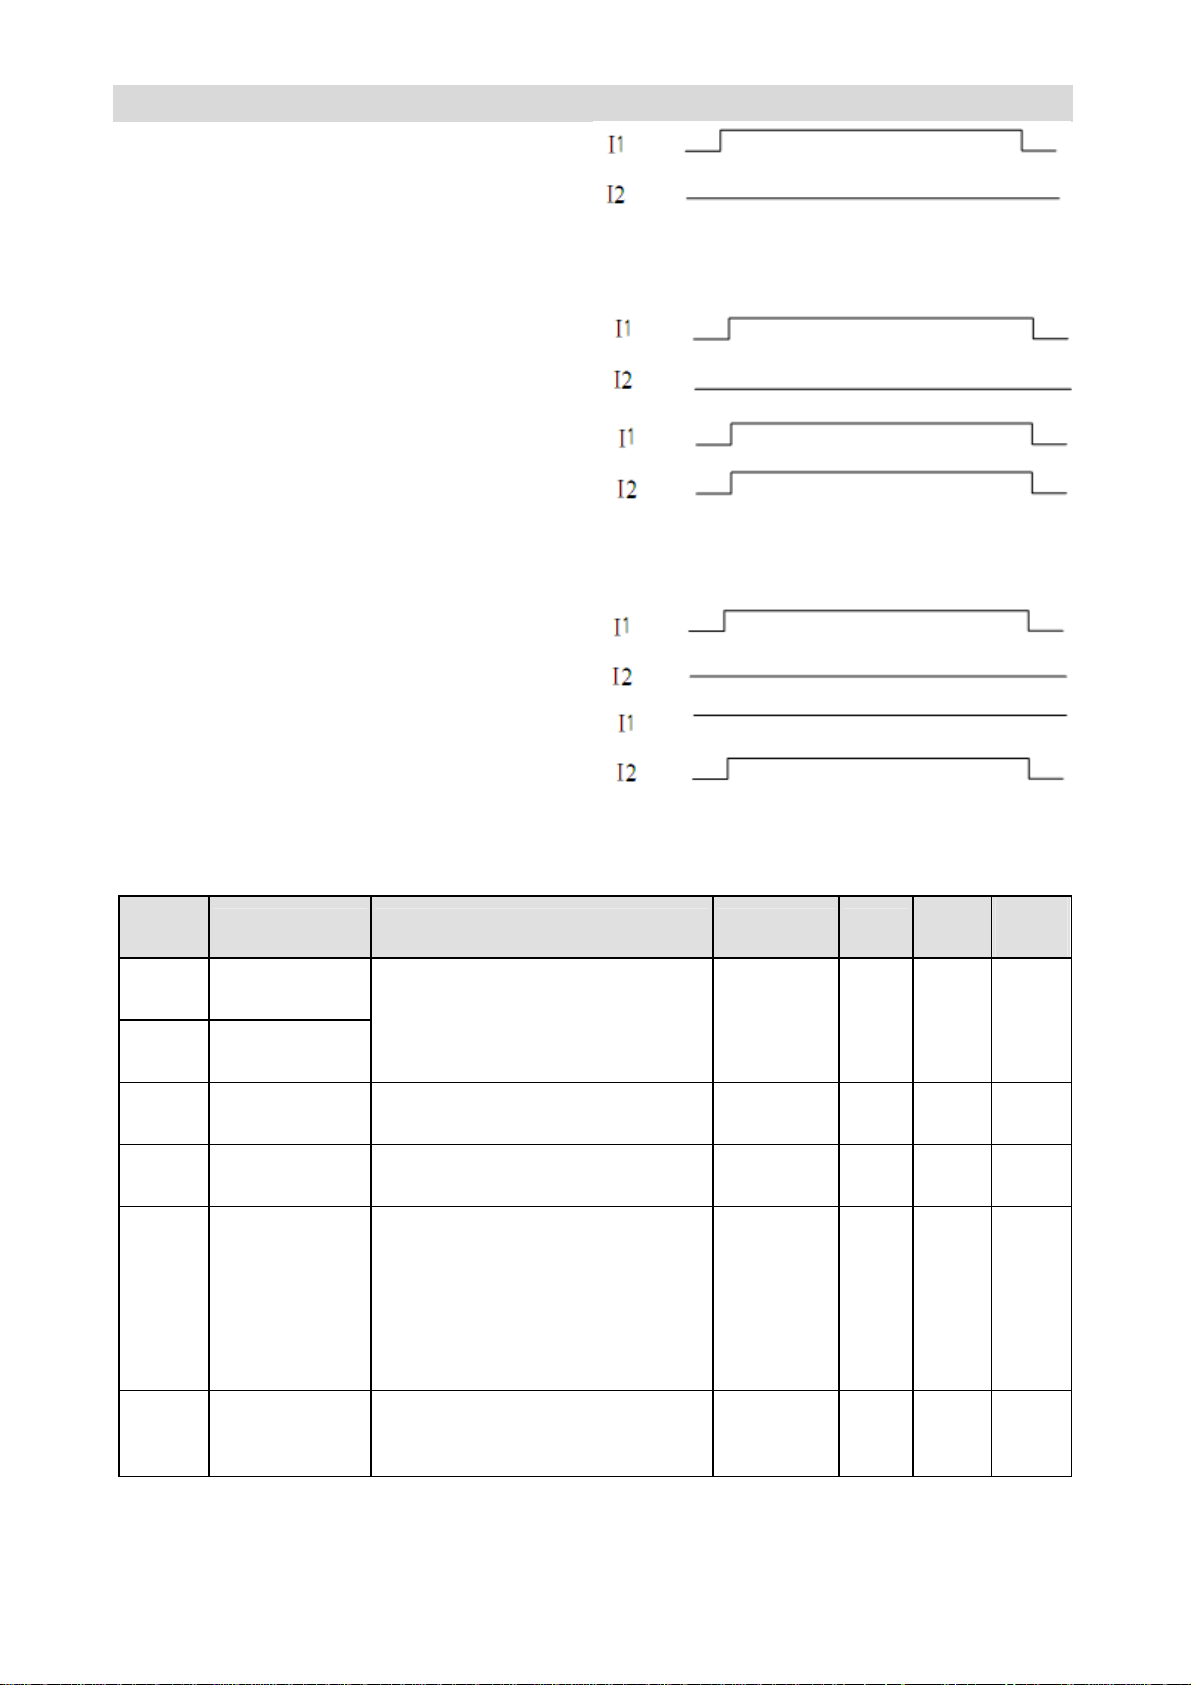
GS DRIVER CTB
Reverse timing sequence diagram
Bn01=0,Bn02=1:
Forward timing sequence diagram
Reverse timing sequence diagram
Bn01=1,Bn02=1:
Forward timing sequence diagram
Reverse timing sequence diagram
Relevant parameters of analog speed setting
Function
code
Cn01
Cn02
Cn03 Analog gain
Cn10
Cn11
Name Description Set range Unit
Analog 0 point
positive offset
Analog 0 point
negative offset
Maximum
output speed
0 point offset
setting in speed
control
To adjust symmetry of analog
against 0 point
Adjust speed offset due to analog
offset
Bipolarity:
0 point offset speed =
Cn11×Cn10/2046
Unipolarity:
0 point offset speed=
Cn11×Cn10/4092
0〜4096 一
0〜100
1〜15000
-10%~10%
Factory
setting
1% 1 X
rpm 8000 X
0.1% 0 X
Modific
ation
0 X
Analog input
Cn18
filtering time
constant
Analog input parameter curve graph
0〜6 一
0 X
Page 93
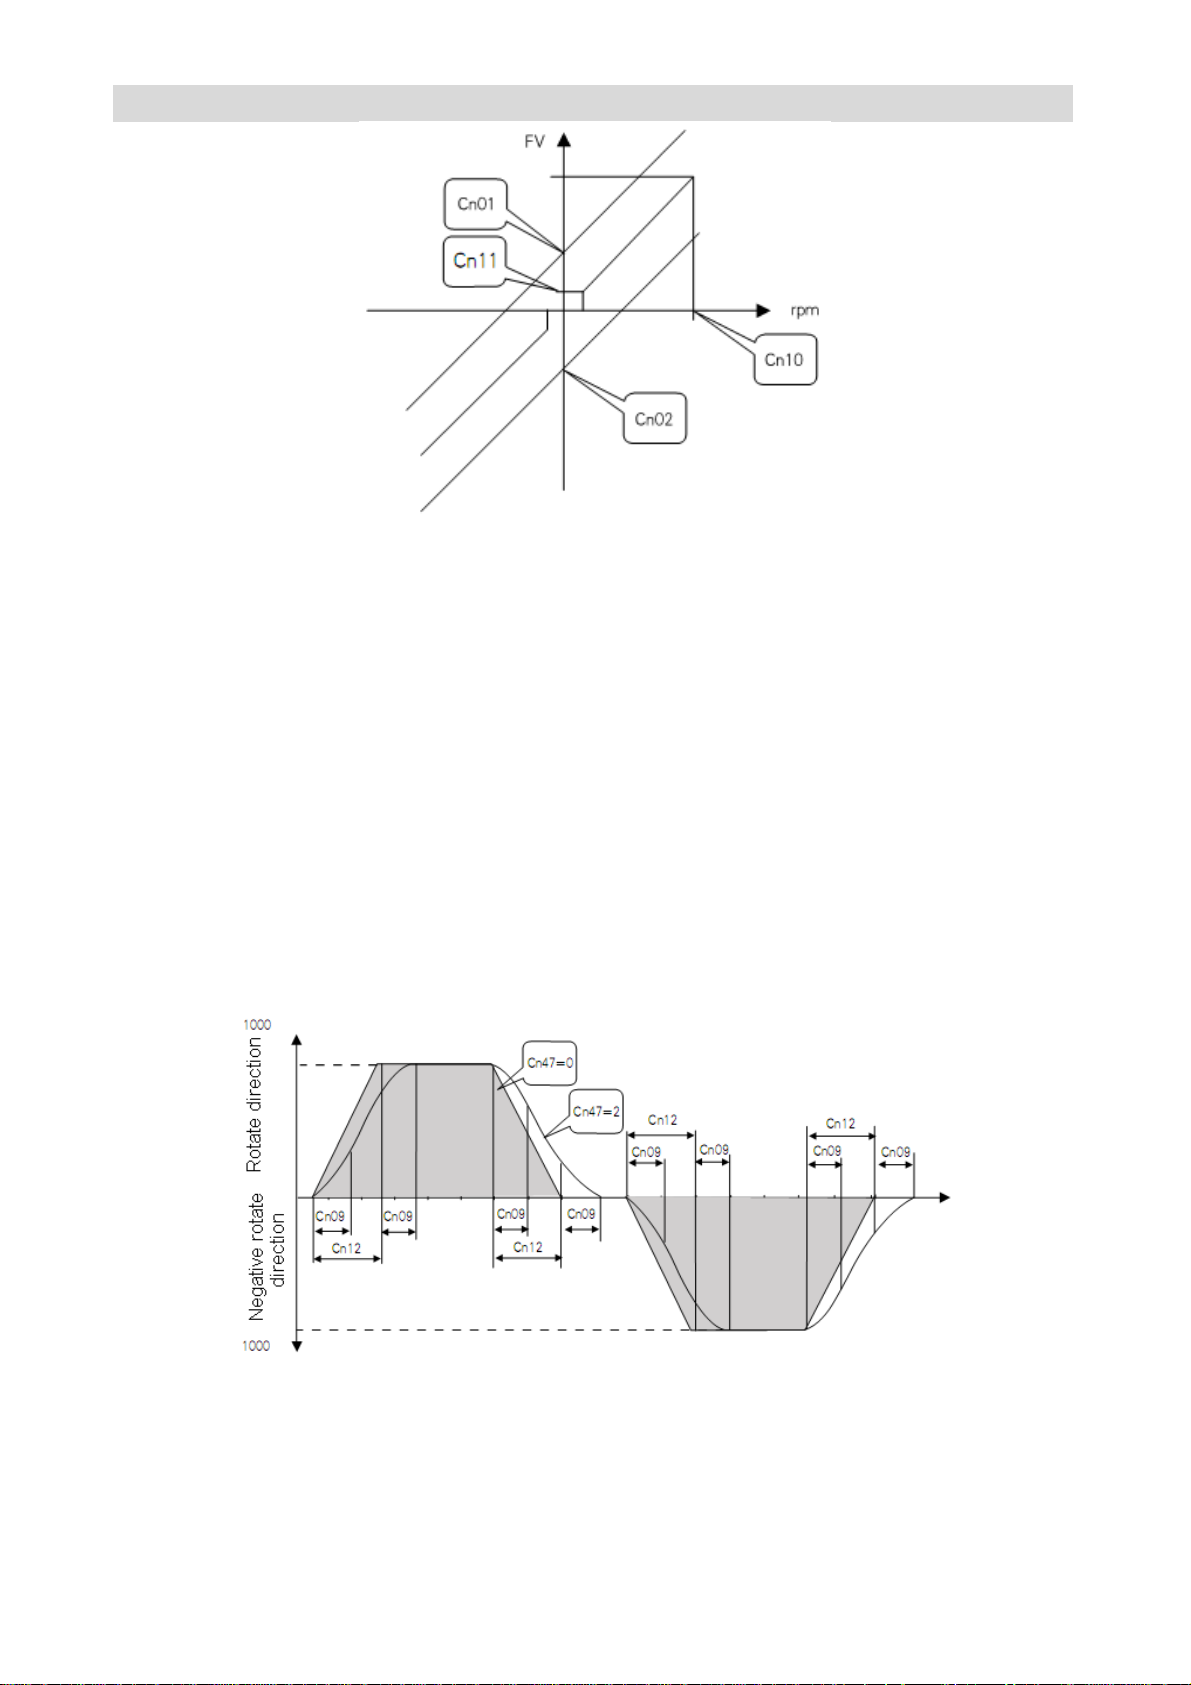
GS DRIVER CTB
Note on parameter setting:
Cn03: set analog gain, 1000 corresponds to 100% to adjust speed offset.
Cn11: for interference to analog when suppress command speed is 0. The speed setting
value is 0 when analog signal is lower than the setting value of the parameter.
Cn18: set analog input filtering time. The speed fluctuation may be too fast due to small
setting, and make spindle vibrate. Setting value set too much may affect speed response of
the spindle.
Acceleration and deceleration control parameters
Acceleration and deceleration control curve
GS driver acceleration and deceleration control curve
Acceleration and deceleration control parameters
Page 94
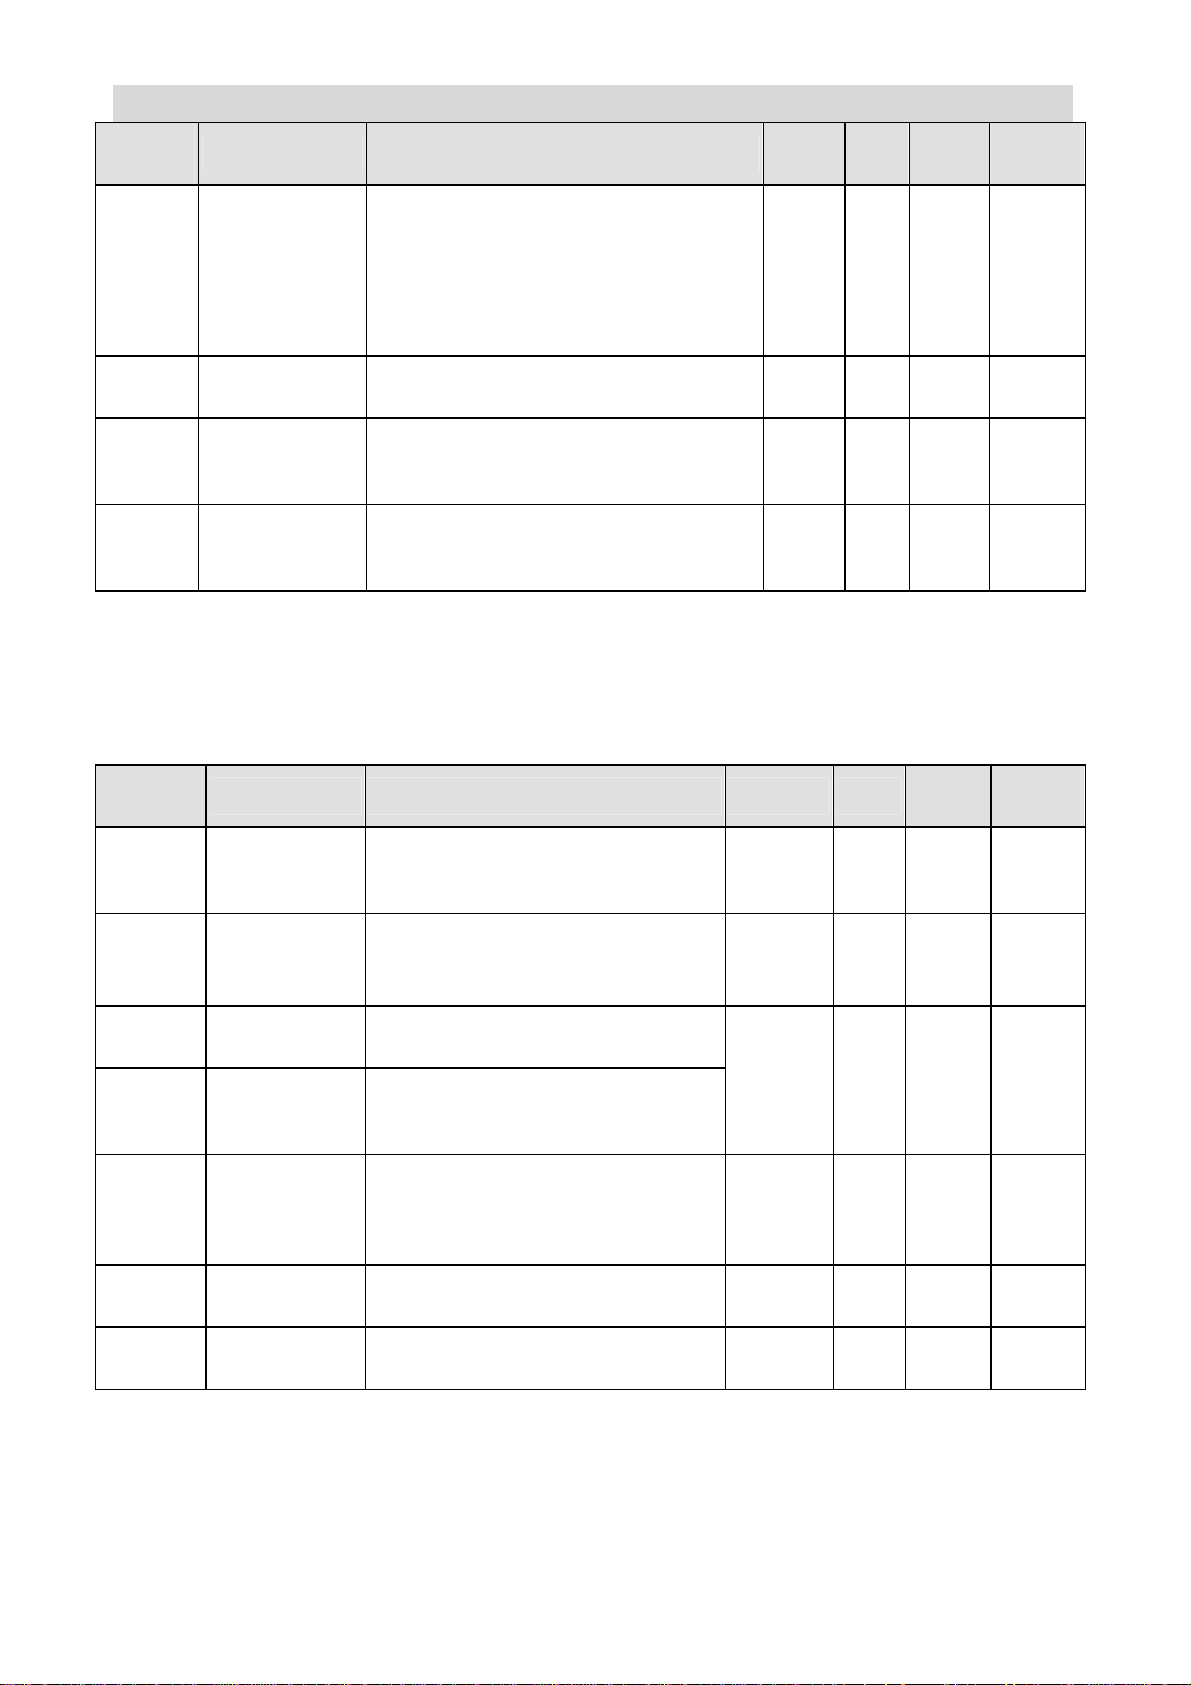
GS DRIVER CTB
Function
code
Cn47
Cn09
Cn12
Cn30
Name Description
0: standard acceleration and deceleration
Acceleration and
deceleration
curve selection
S curve time in
speed control
Spindle
acceleration time
in speed control
Deceleration
time in speed
control
1: acceleration and deceleration curve in
2: acceleration and deceleration curve in
Deceleration time of spindle from 1000〜
Accurate stop parameter
curve (oblique line)
fixed time (without S curve function)
fixed time (with S curve function)
S curve time in speed control
Set spindle acceleration time
0 rpm in speed control
Set
range
0〜2 - 0 X
0~5.00
0〜300
0〜300
0.01S 0 X
Factory
Unit
setting
S 5 X
S 5 X
Modificat
ion
Function
code
Bn03
Bn04
Cn04
Cn05
Cn06
Cn07
Name Description Set range Unit
Positioning
encoder
selection
Accurate stop
signal mode
Accurate stop
offset
Second point
accurate stop
offset
Accurate stop
positioning
speed ring
positioning gain
Accurate stop
speed
0: motor spindle encoder positioning
1: external shaft encoder positioning
0: acceleration stop high electric level
valid
1: acceleration stop PULSE valid
Set position offset against 0 point at
accurate stop
Set position offset against 0 point at
second accurate stop
To adjust rigidity in positioning 0〜32707 - 1000 X
Fine Z-phase PULSE speed of
encoder at accurate stop
0.1 - 0 X
0.1 - 0 X
0〜4
timeshare
encyclope
dia line
number
0〜1000
Factory
setting
PULS
E
rpm 300 X
Modificat
ion
0 X
Cn37
Accurate stop
reach range
Set positioning precision range
Accurate stop process curve graph
0〜32767
PULS
E
2 X
Page 95
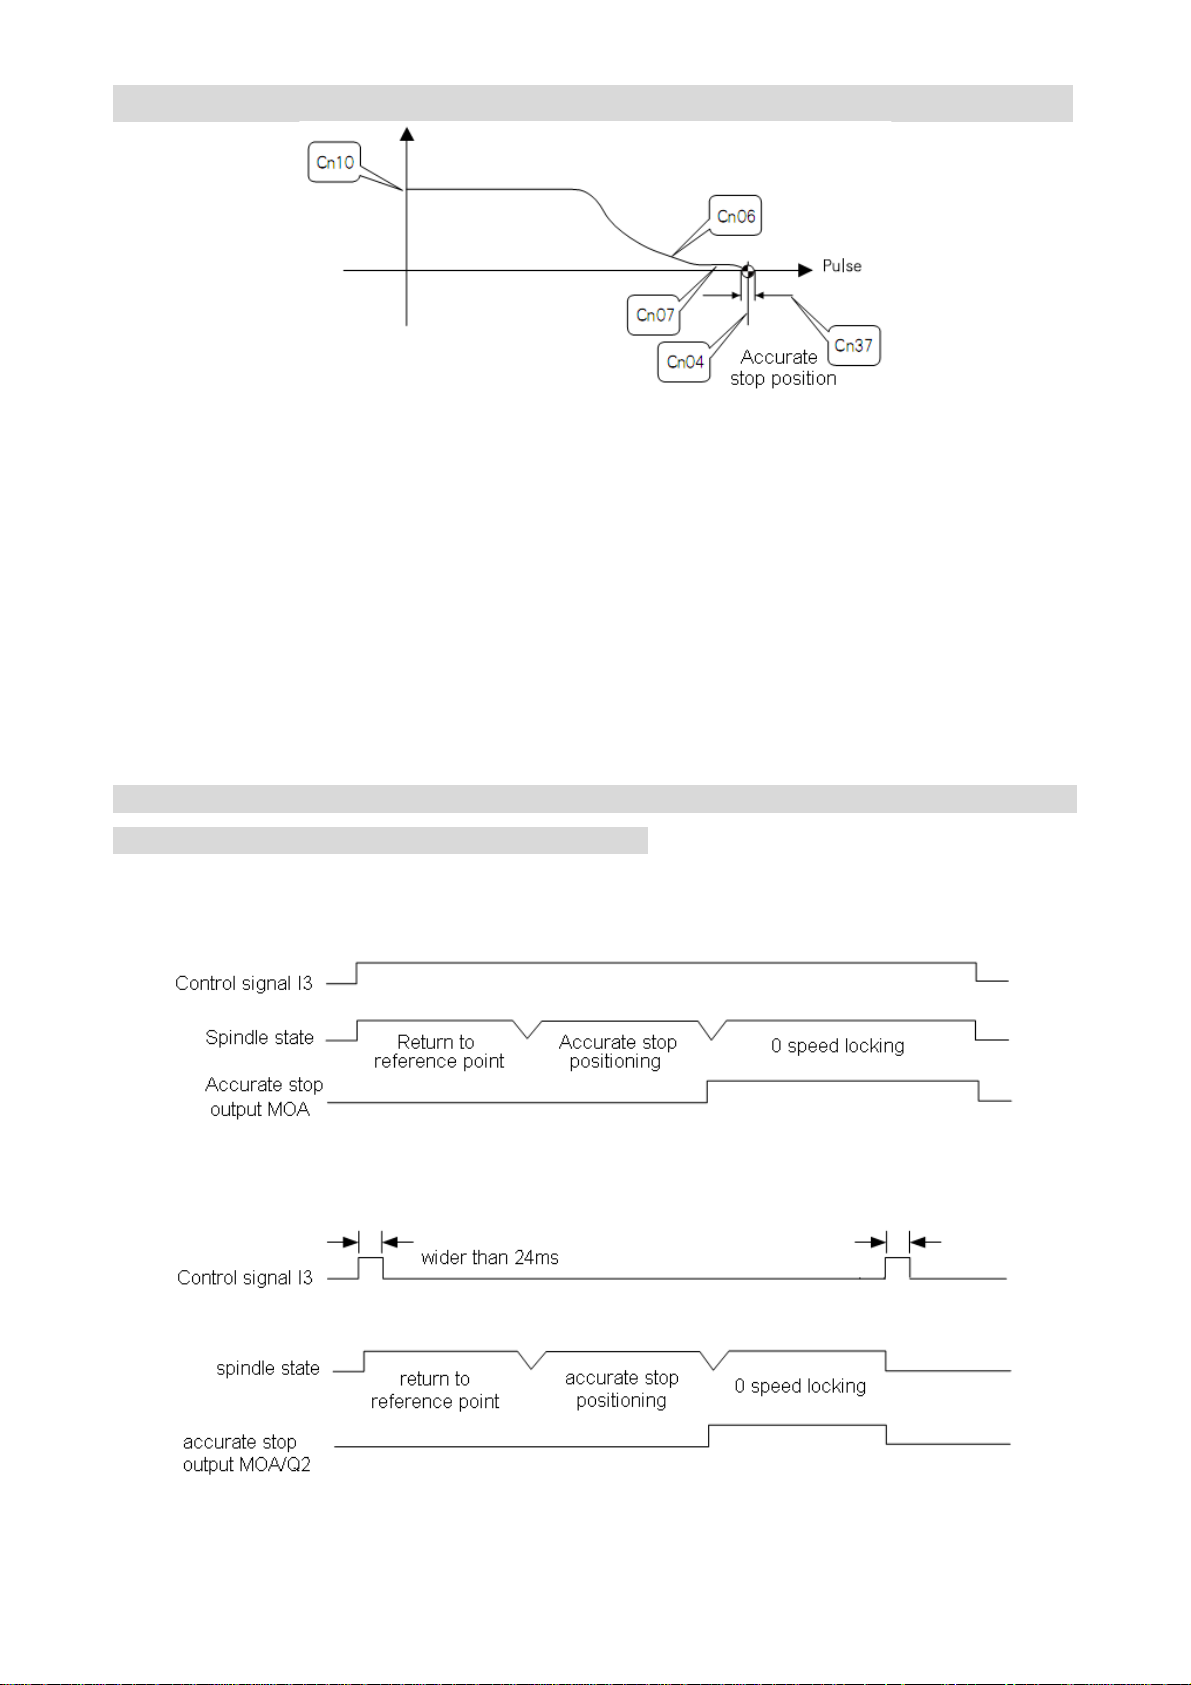
GS DRIVER CTB
Accurate stop process curve graph
Control timing sequence
Bn03: set as 0: motor encoder positioning, for transmission ratio 1:1.
1: external encoder positioning, for spindle with transmission ratio other than 1:1. Intall
spindle positioning of the spindle encoder onto the spindle. At the same time, output
PULSE number per turn of Cn19 spindle encoder shall be set. The spindle encoder shall be
connected to T4 plug of the driver.
Note: If external encoder positioning is used, the spindle must rotate one round after
power-on of the driver and prior to first positioning.
Bn04: accurate stop signal mode; 0: acceleration stop high electric level valid
(recommended). Timing sequence is as shown in the following figure:
1: accurate stop PULSE is valid. The mode only can be used by input signal again to lift
locking of the motor.
Page 96
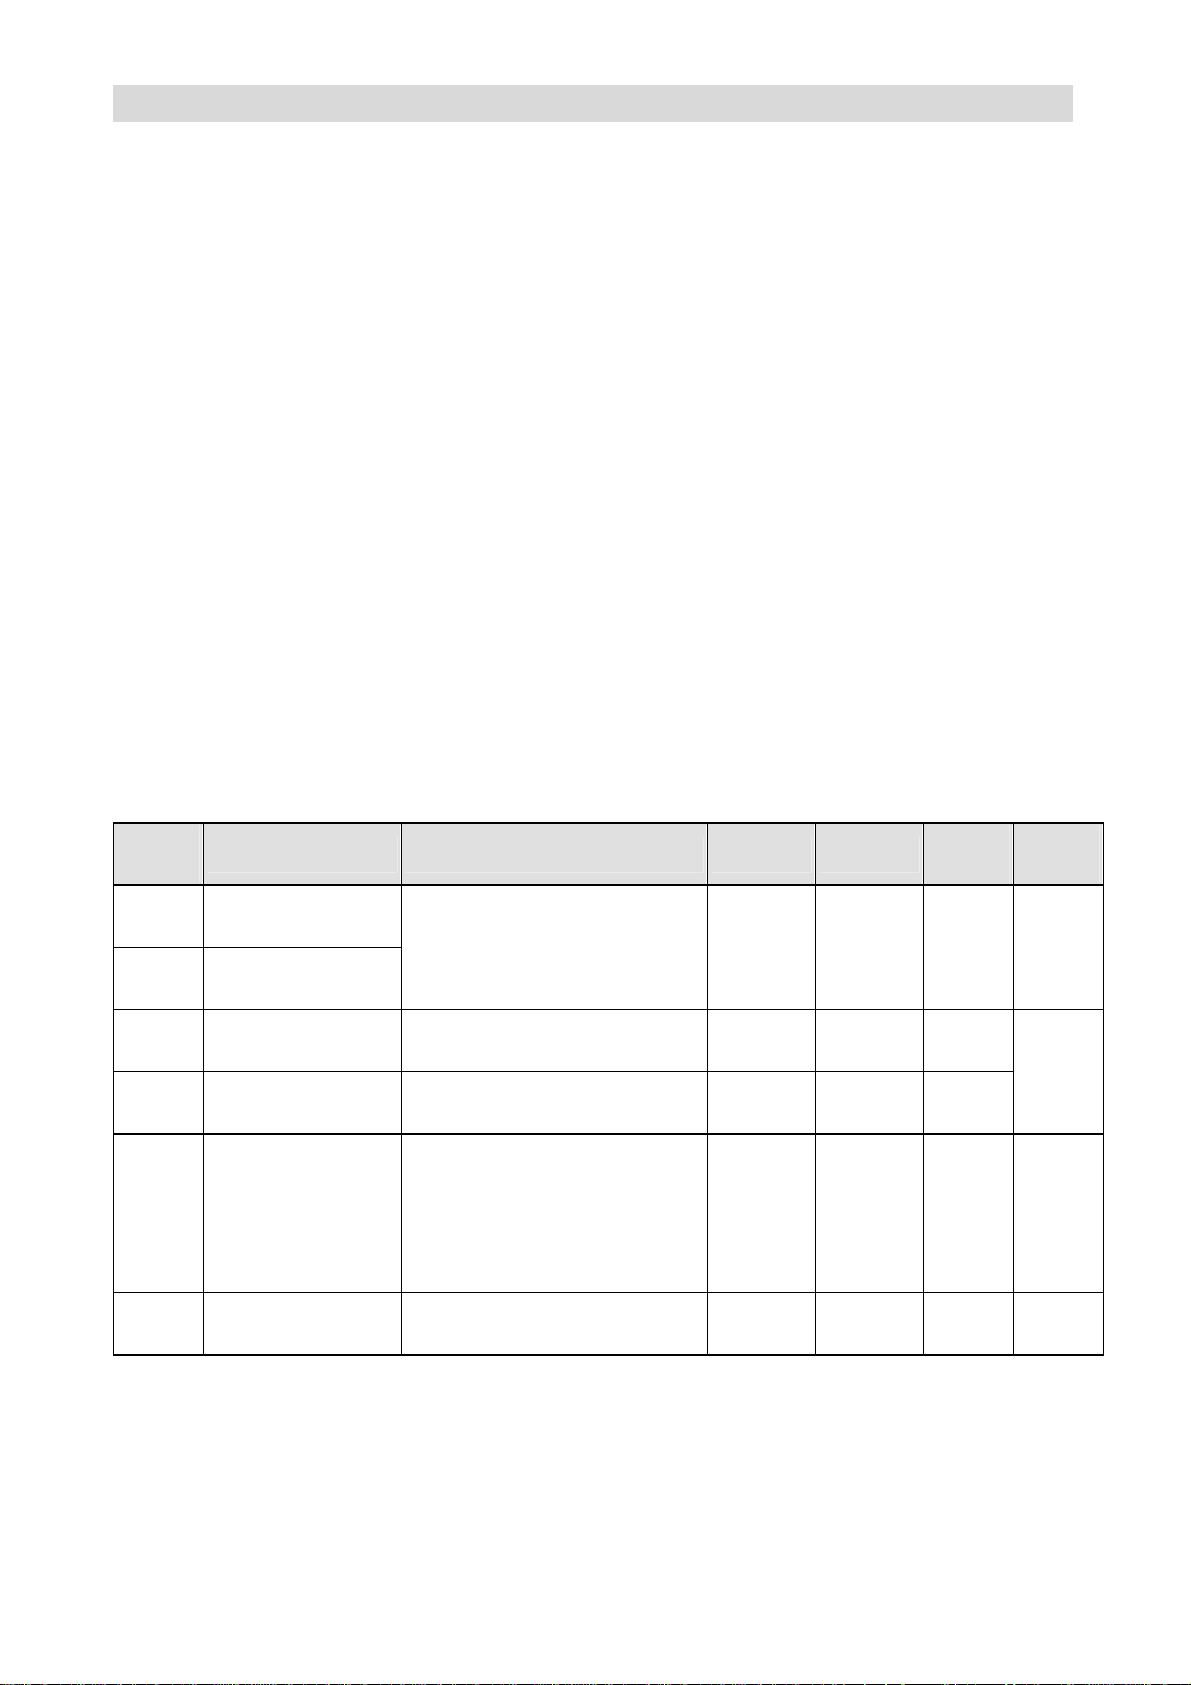
GS DRIVER CTB
Parameter settings note
Cn06: positioning gain in accurate signal stop. The parameter sets deceleration gain during
spindle accurate stop positioning. The positioning is slow if the value is too small, and
positioning accuracy may by affected or cause shock to the spindle if it's too great.
Cn07: spindle accurate stop speed. The parameter sets speed of finding encoder Z phase
at the start second of spindle positioning. The set value will affect speed and accuracy of
positioning of spindle.
The above two parameters are usually not recommended to modify by user.
Spindle accurate stop position setting
Manual adjustment:
1: The spindle shall perform one accurate stop firstly, and then release.
2: Rotate motor or spindle manually to position of accurate stop.
3: Observe value in menu U2-11, and then fill it in Cn04.
4: For small deviation at accurate stop position, it may be adjusted manually on the basis of
Cn04 value.
Rigid tapping
Function
code
Cn01
Cn02
Cn03 Analog gain
Cn20
Cn21
Name Description Set range Unit
Analog 0 point
positive offset
Analog 0 point
negative offset
Rigid tapping
maximum speed
Rigid tapping
(PULSE position)
control 0 speed
proportional gain
To adjust symmetry of analog
against 0 point
Actual speed setting =analog
sampling value X Cn03
Set maximum speed of rigid
tapping
Set speed ring adjuster
proportional gain during rigid
tapping (PULSE position ) 0
speed control. The gain and
rigidity is higher as the set value
is greater.
0〜4096
1〜1500
0〜3000
1〜32767 - 100 ×
- 0
0.1% 1000
rpm 1500
Factory
setting
Modifica
tion
×
×
Cn22
Rigid tapping
acceleration
Set spindle acceleration during
rigid tapping
0〜30000
0.05Hz/s 5000 X
Control timing sequence
When use analog as speed setting, and I4 input signal is valid, the timing sequence is as
follows as the spindle enters rigid tapping state.
Page 97
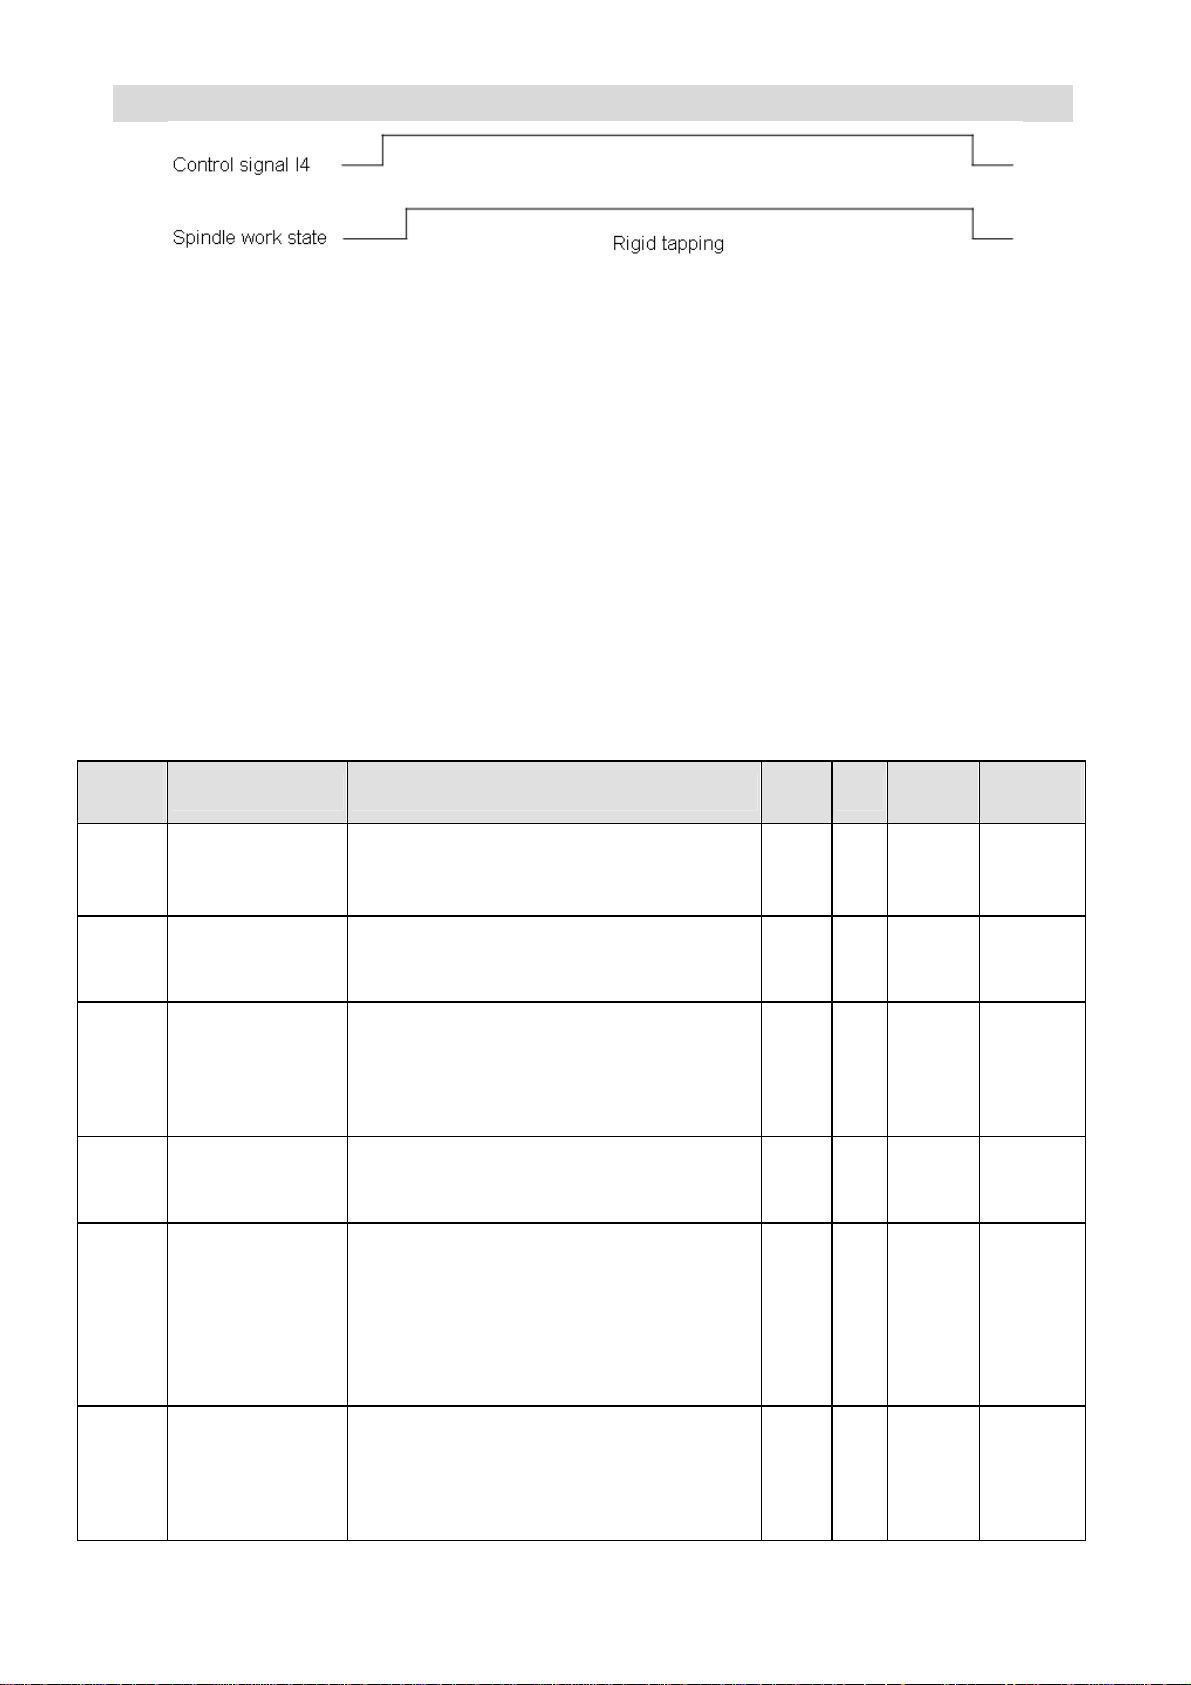
GS DRIVER CTB
Note on rigid tapping
1. To adapt to the rapid response and control accuracy of the spindle, the driver will
automatically adjust the relevant parameters of the control after entering rigid tapping state.
2. During rigid tapping, the spindle participates interpolation control of coordinate axis as a
position axis. At the moment, it's required that the CNC system shall switch control of
spindle to position axis control.
3. During rigid tapping, the maximum speed of the CNC system shall be consistent with
maximum speed of the driver, and analog voltage shall be adjusted to be symmetrical to 0V
through driver or the CNC system.
PULSE control
Function
code
Bn16
Bn22
Cn21
Cn23
Cn24
Name Description
PULSE mode
selection
Rigid tapping
(PULSE position)
acceleration time
Rigid tapping
(PULSE position)
control 0 zero
speed
proportional gain
Rigid tapping
(PULSE position)
deceleration time
PULSE position
control position
ring proportional
gain
0: direction +PULSE 2:
CW/CCW
1: 90°orthogonal PULSE
Set acceleration time of motor from 0-1000
rpm when the spindle is in rigid tapping /
PULSE position.
Set speed ting adjust proportional gain
during rigid tapping (PULSE position)
control zero speed. The gain and rigidity are
higher with greater setting value.
Set deceleration time of motor from 0-1000
rpm when the spindle is in rigid tapping /
PULSE position.
Set position ring adjuster proportional gain
during position control. The gain and rigidity
are higher with greater setting value, and
the position lagging is smaller with same
frequency command PULSE, however, the
too small value may cause vibration or over
control.
Set
range
0 - 0 X
0〜
300
1〜
32767
0〜
300
0〜
32767
Factory
Unit
setting
S 1 X
-
S 1 X
-
100 X
500 X
Modificati
on
Cn25
Rigid tapping
(PULSE position)
speed ring
proportional gain
Set speed ring adjuster proportional gain in
speed control. The gain and rigidity are
higher with greater setting value. Please set
the value as big as possible without
vibration generated in the system.
0〜
32767
-
100 X
Page 98
GS DRIVER CTB
Cn26
Cn27
Cn28
Cn29
Cn32
Cn33
Rigid tapping
(PULSE position)
speed integration
time constant
Rigid tapping
(PULSE position)
S curve time
Rigid tapping
(PULSE position)
current ring
proportional gain
Rigid tapping
(PULSE position)
current ring
integration time
PULSE command
multiplying power
numerator
PULSE command
multiplying power
denominator
Set speed ring adjuster integration time
constant in speed control. The gain and
rigidity are higher with smaller setting value.
Please set the value as small as possible
without vibration generated in the system.
S curve time during rigid tapping (PULSE
position) control
Set current ring proportion during rigid
tapping or PULSE position
Set integration value of current ring during
rigid tapping or PULSE position
Set multiplying power numerator of position
command PULSE (electronic gear)
Set multiplying power denominator of
position command PULSE (electronic gear)
0〜
32767
0〜
5.00
1〜
150
1〜
150
一
32000
~3200
0
1〜
32000
-
0.01
s
- 80 X
- 80 X
-
-
500 X
0 X
1000 X
1000 X
Control mode selection
As shown in Table 6-1, function selection may be carried out through control signal when
using PULSE control mode and PULSE input.
Table 6-1 Control mode selection
Control terminal Function
PULSE position control is for C shaft function, rigid tapping and other
I4
accurate position control functions.
PULSE speed control is for applications in which spindle is used as
I1
speed shaft.
Page 99
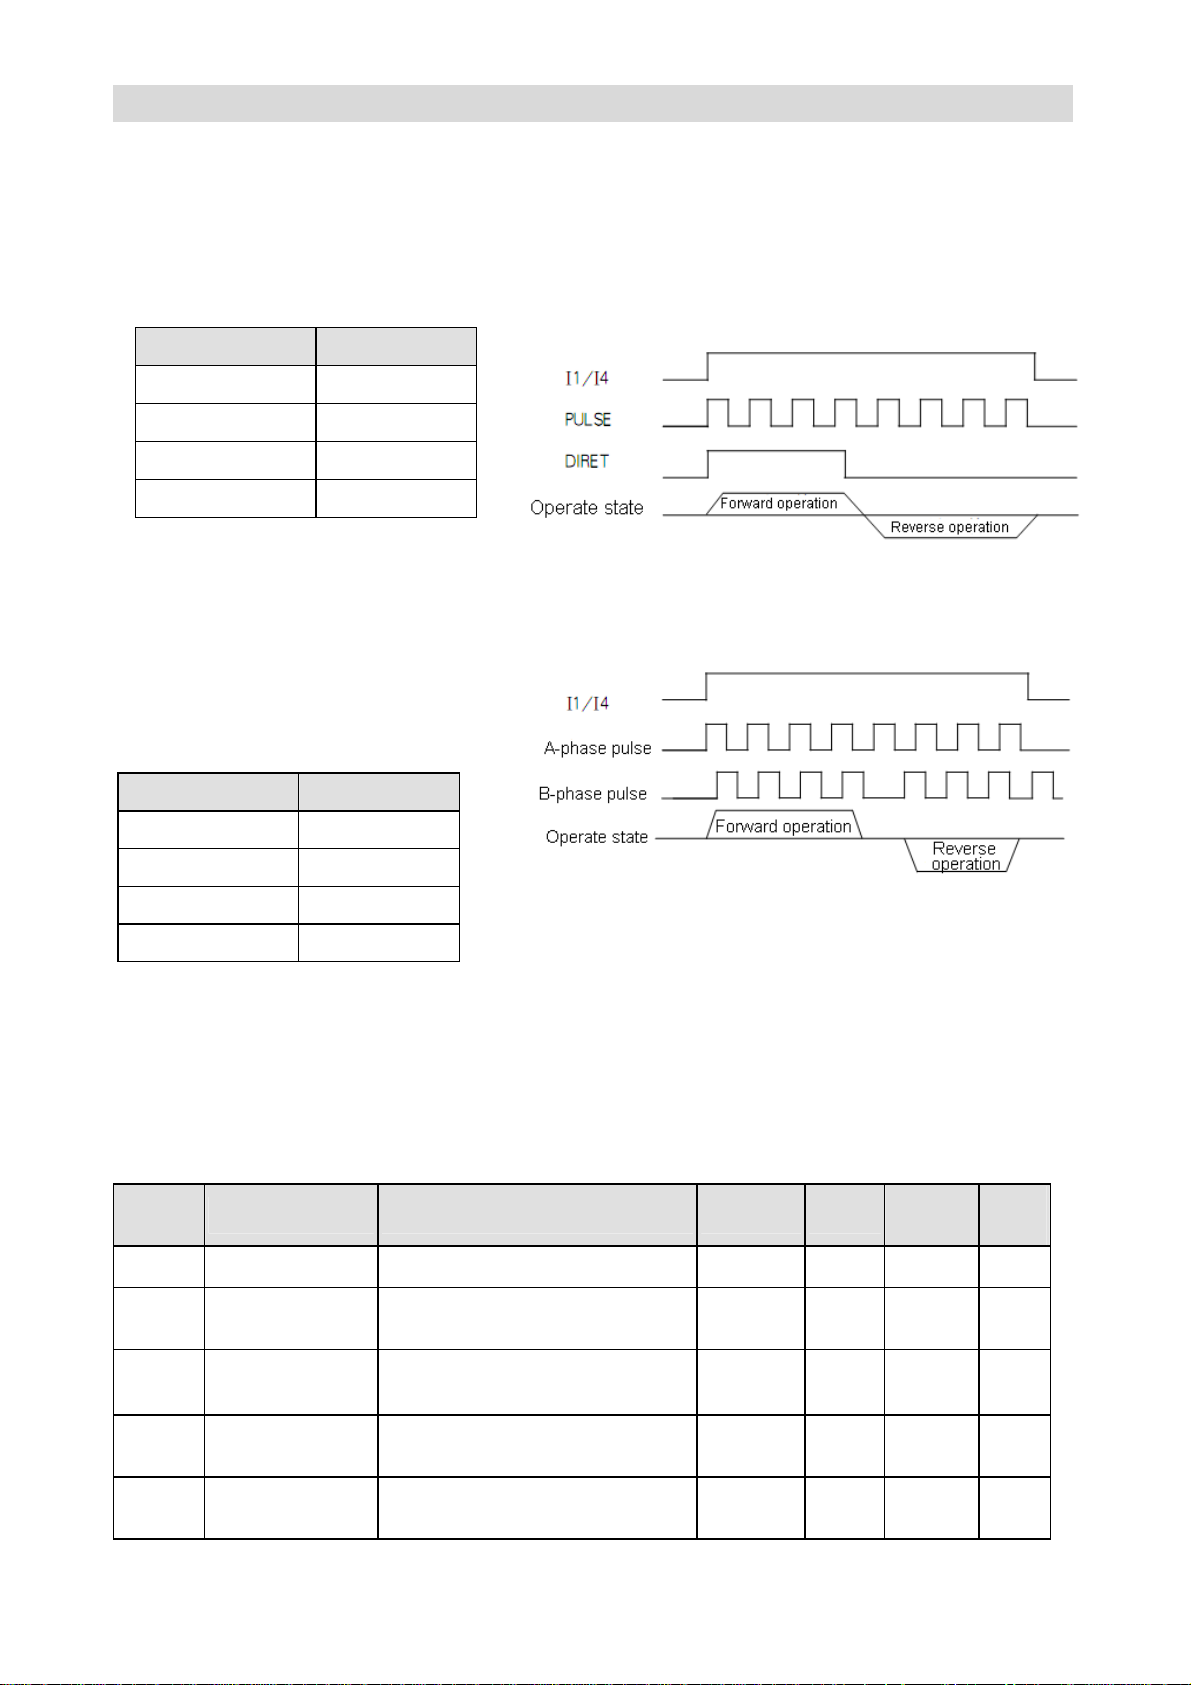
GS DRIVER CTB
Please see Table 7-2 for direction+
PULSE control interface. The control
timing sequence is shown in the right
figure.
Table 7-2 PULSE interface of CNC
system with GS series product
Control terminal Function
SA+ PULSE+
SA- PULSE-
Pb+ DIR+
Pb- DIR-
Please see Table 7-3 for 90°orthogonal
PULSE control interface. The control
timing sequence is shown in the right
figure.
Direction +PULSE input operating timing sequence diagram
90°orthogonal PULSE operating timing sequence diagram
Table 7-3 PULSE interface of CNC
system with GS series product
Control terminal Function
SA+ PA+
SA- PA-
Pb+ Pb+
Pb- Pb-
Swing control
Spindle swing is generally used for automatic shift of spindle system. Please see Cn40,
Cn41, Cn42 and Cn43 for spindle swing related parameters
Function
code
Cn40 Swing speed Set swing speed 0〜3000 rpm 1500 X
Name Description Set range Unit
Factory
setting
Modifi
cation
Cn41
Cn42
Cn43
Cn44
Positive swing
amplitude
Negative swing
amplitude
Swing control
acceleration time
Swing control
deceleration time
Set the maximum angle of
positive swing
Set the maximum angle of
negative swing
Set motor acceleration time when
the spindle in swing control
Set motor deceleration time when
the spindle in swing control
0〜32767
0〜一
32767
0〜300
0〜300
PULSE 100 X
PULSE 100 X
S 1 X
S 1 X
Page 100
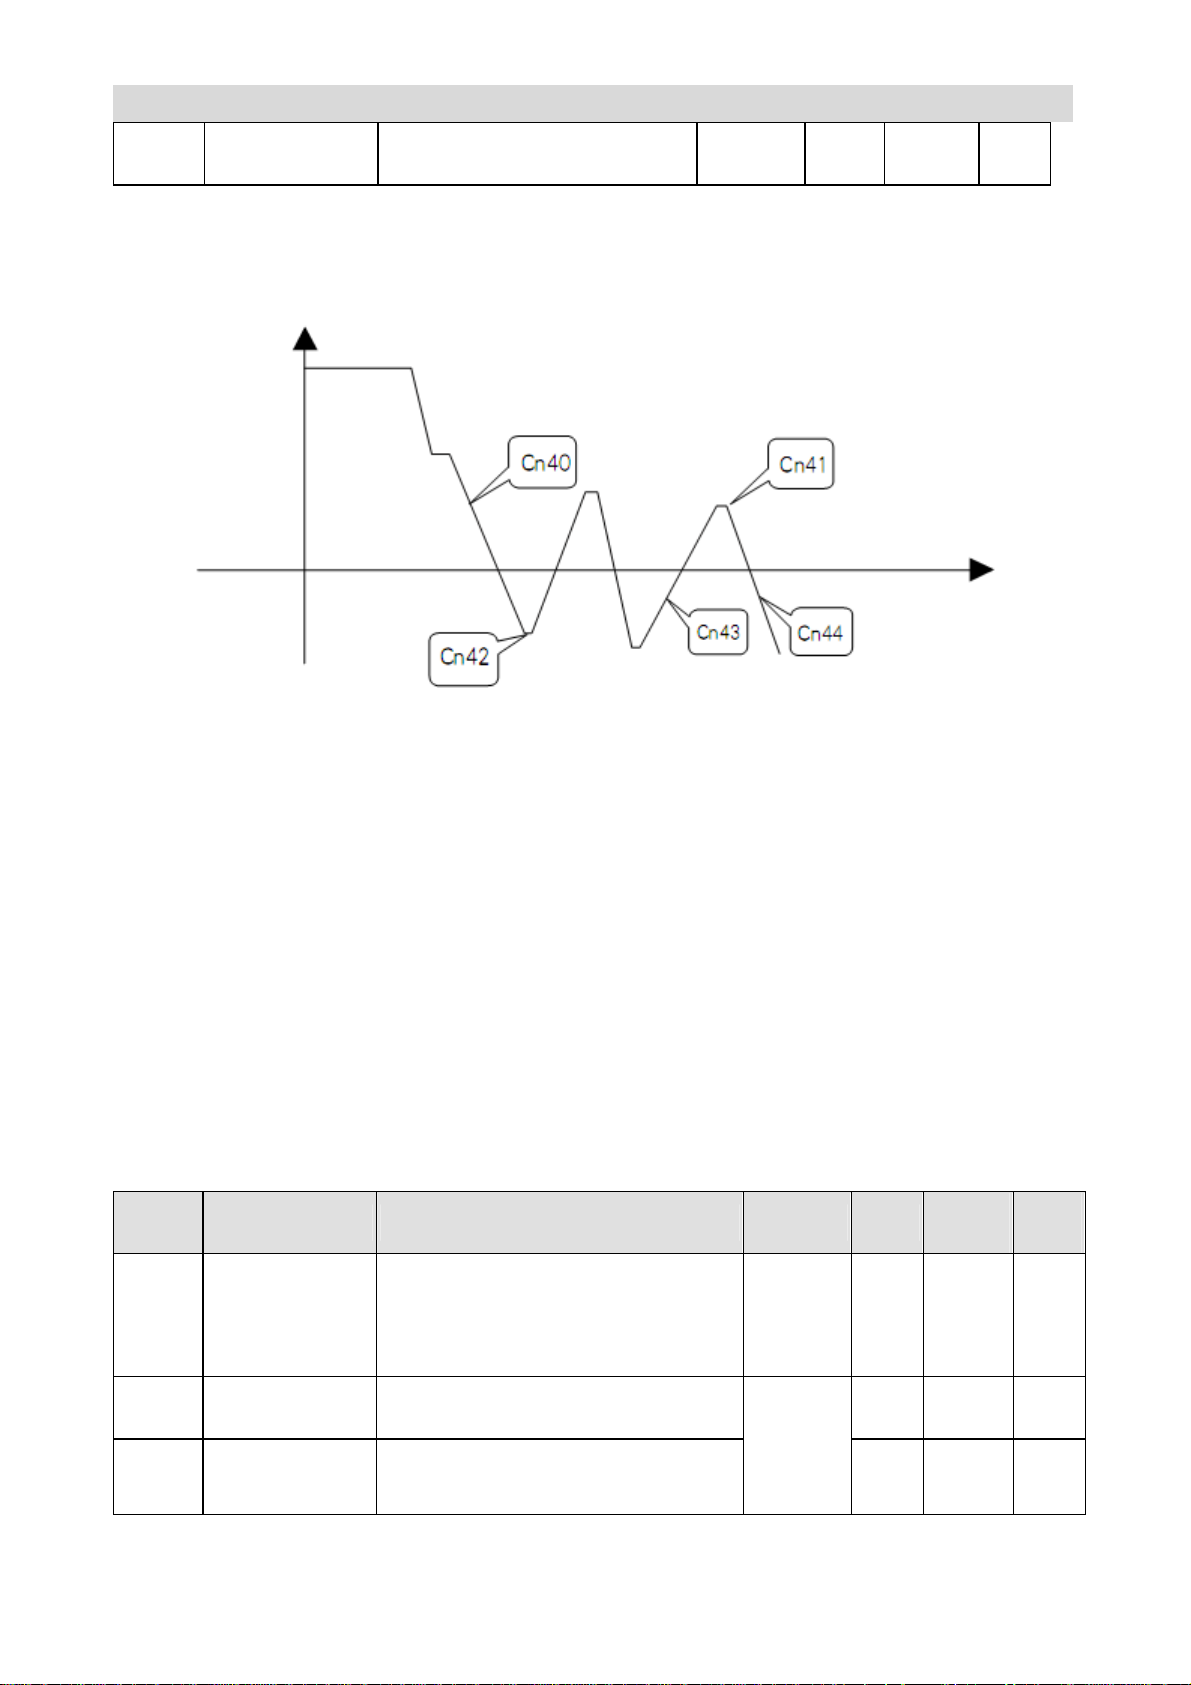
GS DRIVER CTB
Cn45 Swing torque limit
Set the maximum output torque
of the driver during swing
0〜1000
nm 20 X
Control method
GS driver enters swing control function when the I6 terminal is valid; when signal of I6
terminal is canceled, spindle decelerates 0 speed, and maintain a free state.
Multi-function terminal control
Multi-function terminal I5 may select different control functions as required by user. The
function selection may be set through Bn30 parameters.
Second accurate stop function
Second accurate stop function is for second fixed point positioning as required by user.
Note: When second accurate stop is used, function of I5 will become the first, second
symbol selecting signal, at the same time, Cn05 will be taken as second accurate stop
position offset setting value.
Second accurate stop parameters
Function
code
Bn30
Name Description Set range Unit
Multifunction
terminal I5
function selection
0: invalid 3: 0 speed function
1: second accurate stop function 4:
external fault input
2: low-speed function
― ― 1 X
Factory
setting
Modifi
cation
Cn04
Cn05
Accurate stop
offset
Second accurate
stop offset
Set position offset against 0 point
during accurate stop
Set position offset against 0 point
during second point accurate stop
0〜4
timeshare
encoder
line
number
PULS
E
PULS
E
0 X
0 X
 Loading...